

Patents
Literature
99 results about "Lighting-up time" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
In the United Kingdom, there is a legally enforced lighting-up time, defined as from half an hour after sunset to half an hour before sunrise, during which all motor vehicles on unlit public roads (except if parked) must use their headlights.
Spontaneous light emitting device and driving method thereof
A counter 102 counts the accumulated lighting time or the accumulated lighting time and the intensity of lighting of each pixel by a first image signal 101A and stores them in a volatile memory 103 or a nonvolatile memory 104. A correction circuit 105 corrects the first image signal based on the correction data stored previously in a correction data storage section 106 in accordance with the degree of the degradation of each spontaneous light emitting element by the use of the accumulated lighting time or the accumulated lighting time and the intensity of lighting, and produces a second mage signal 101B. By the second image signal 101B, a display unit 107 can provide a uniform screen having no variation in luminance even if the light emitting elements in a part of the pixels are degraded.
Owner:SEMICON ENERGY LAB CO LTD
Liquid crystal display device
InactiveUS8159432B2Reduce dependenceReduce viewing angle dependenceCathode-ray tube indicatorsNon-linear opticsLiquid-crystal displayLighting-up time
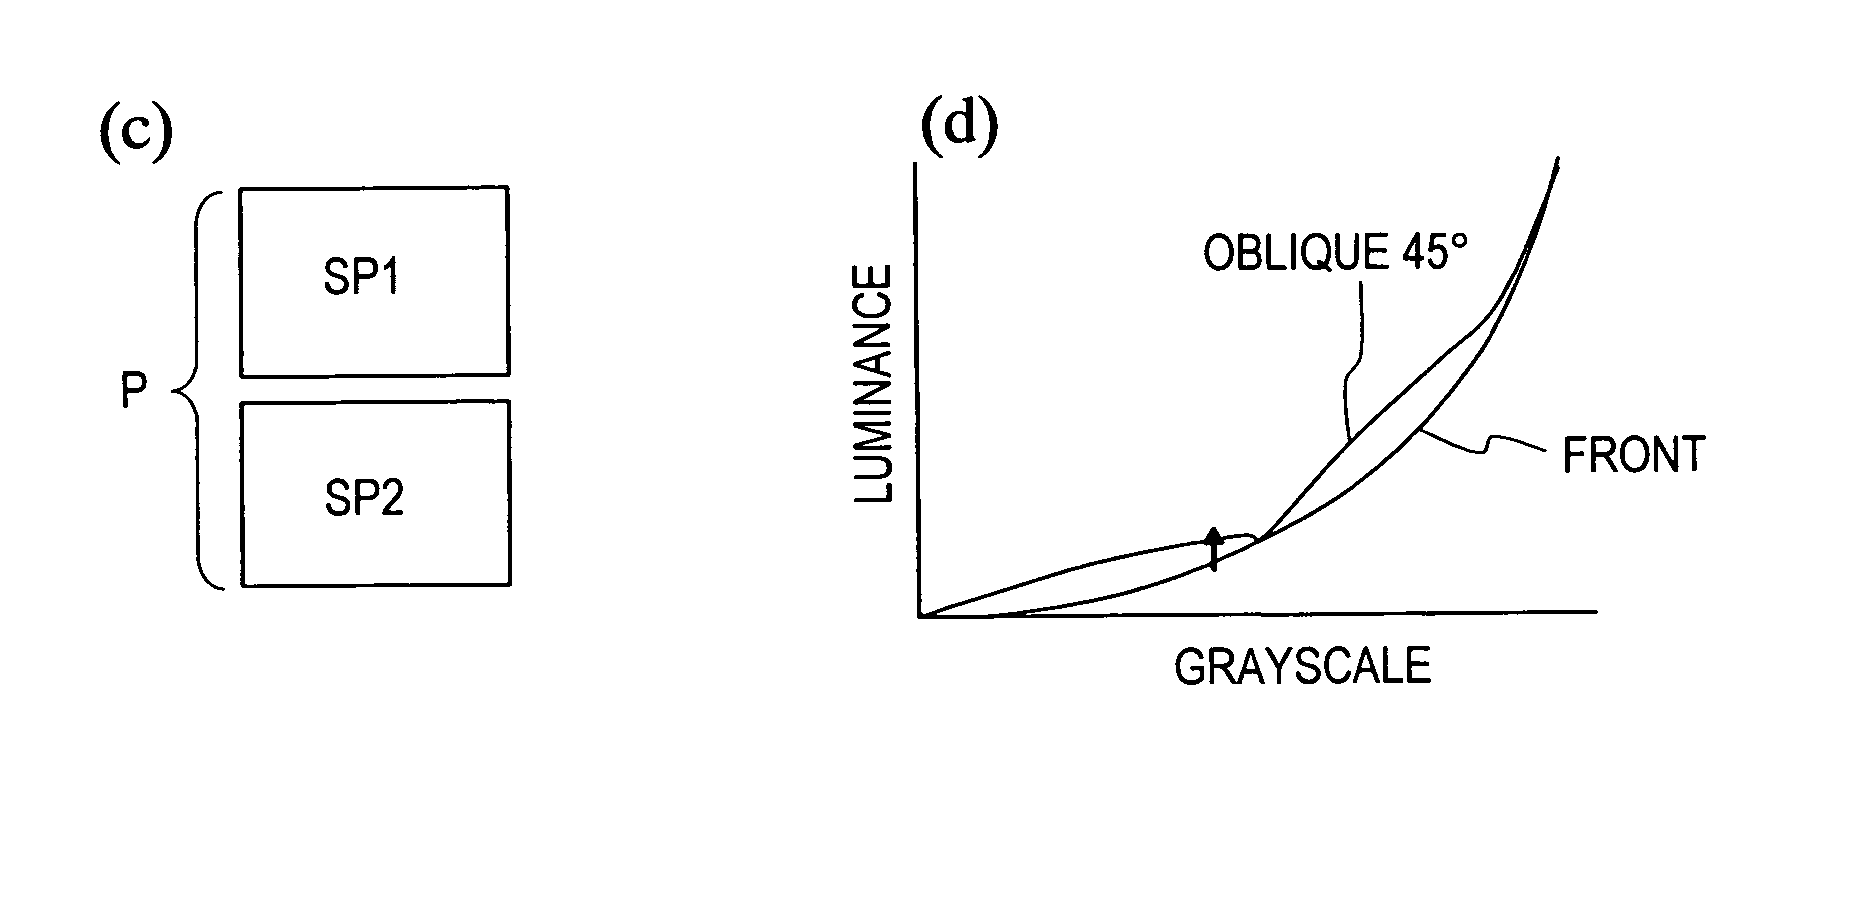
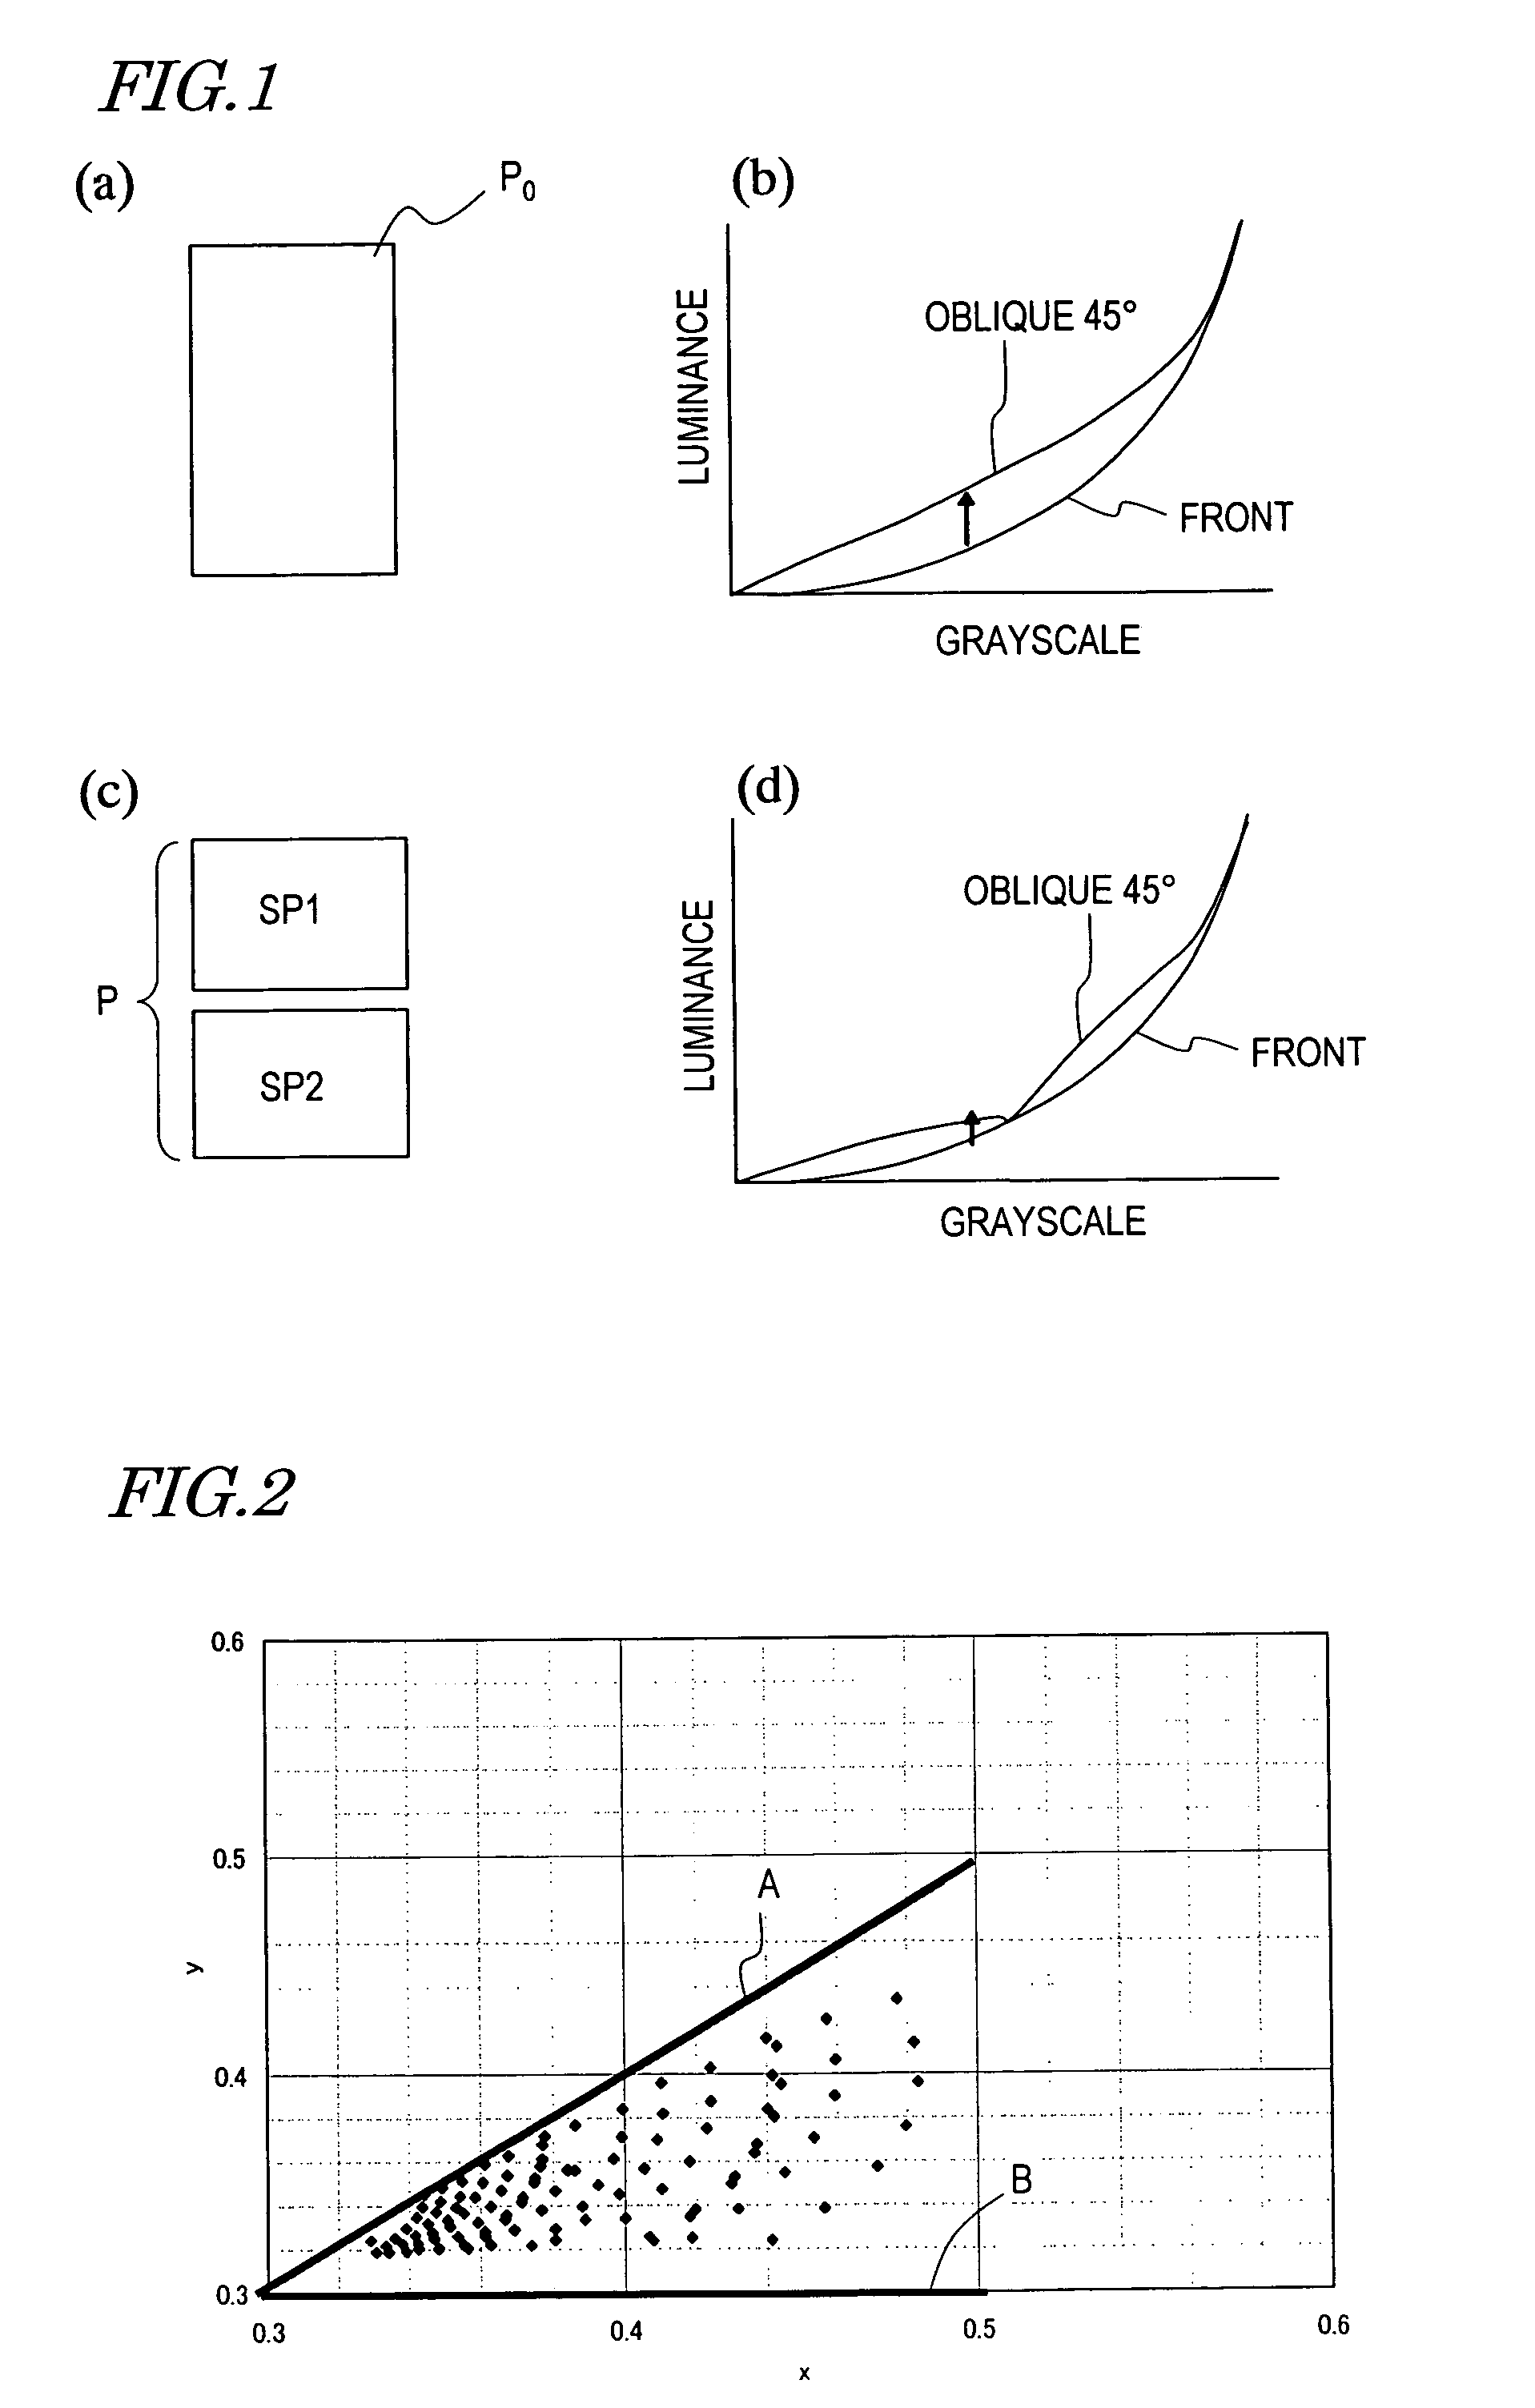
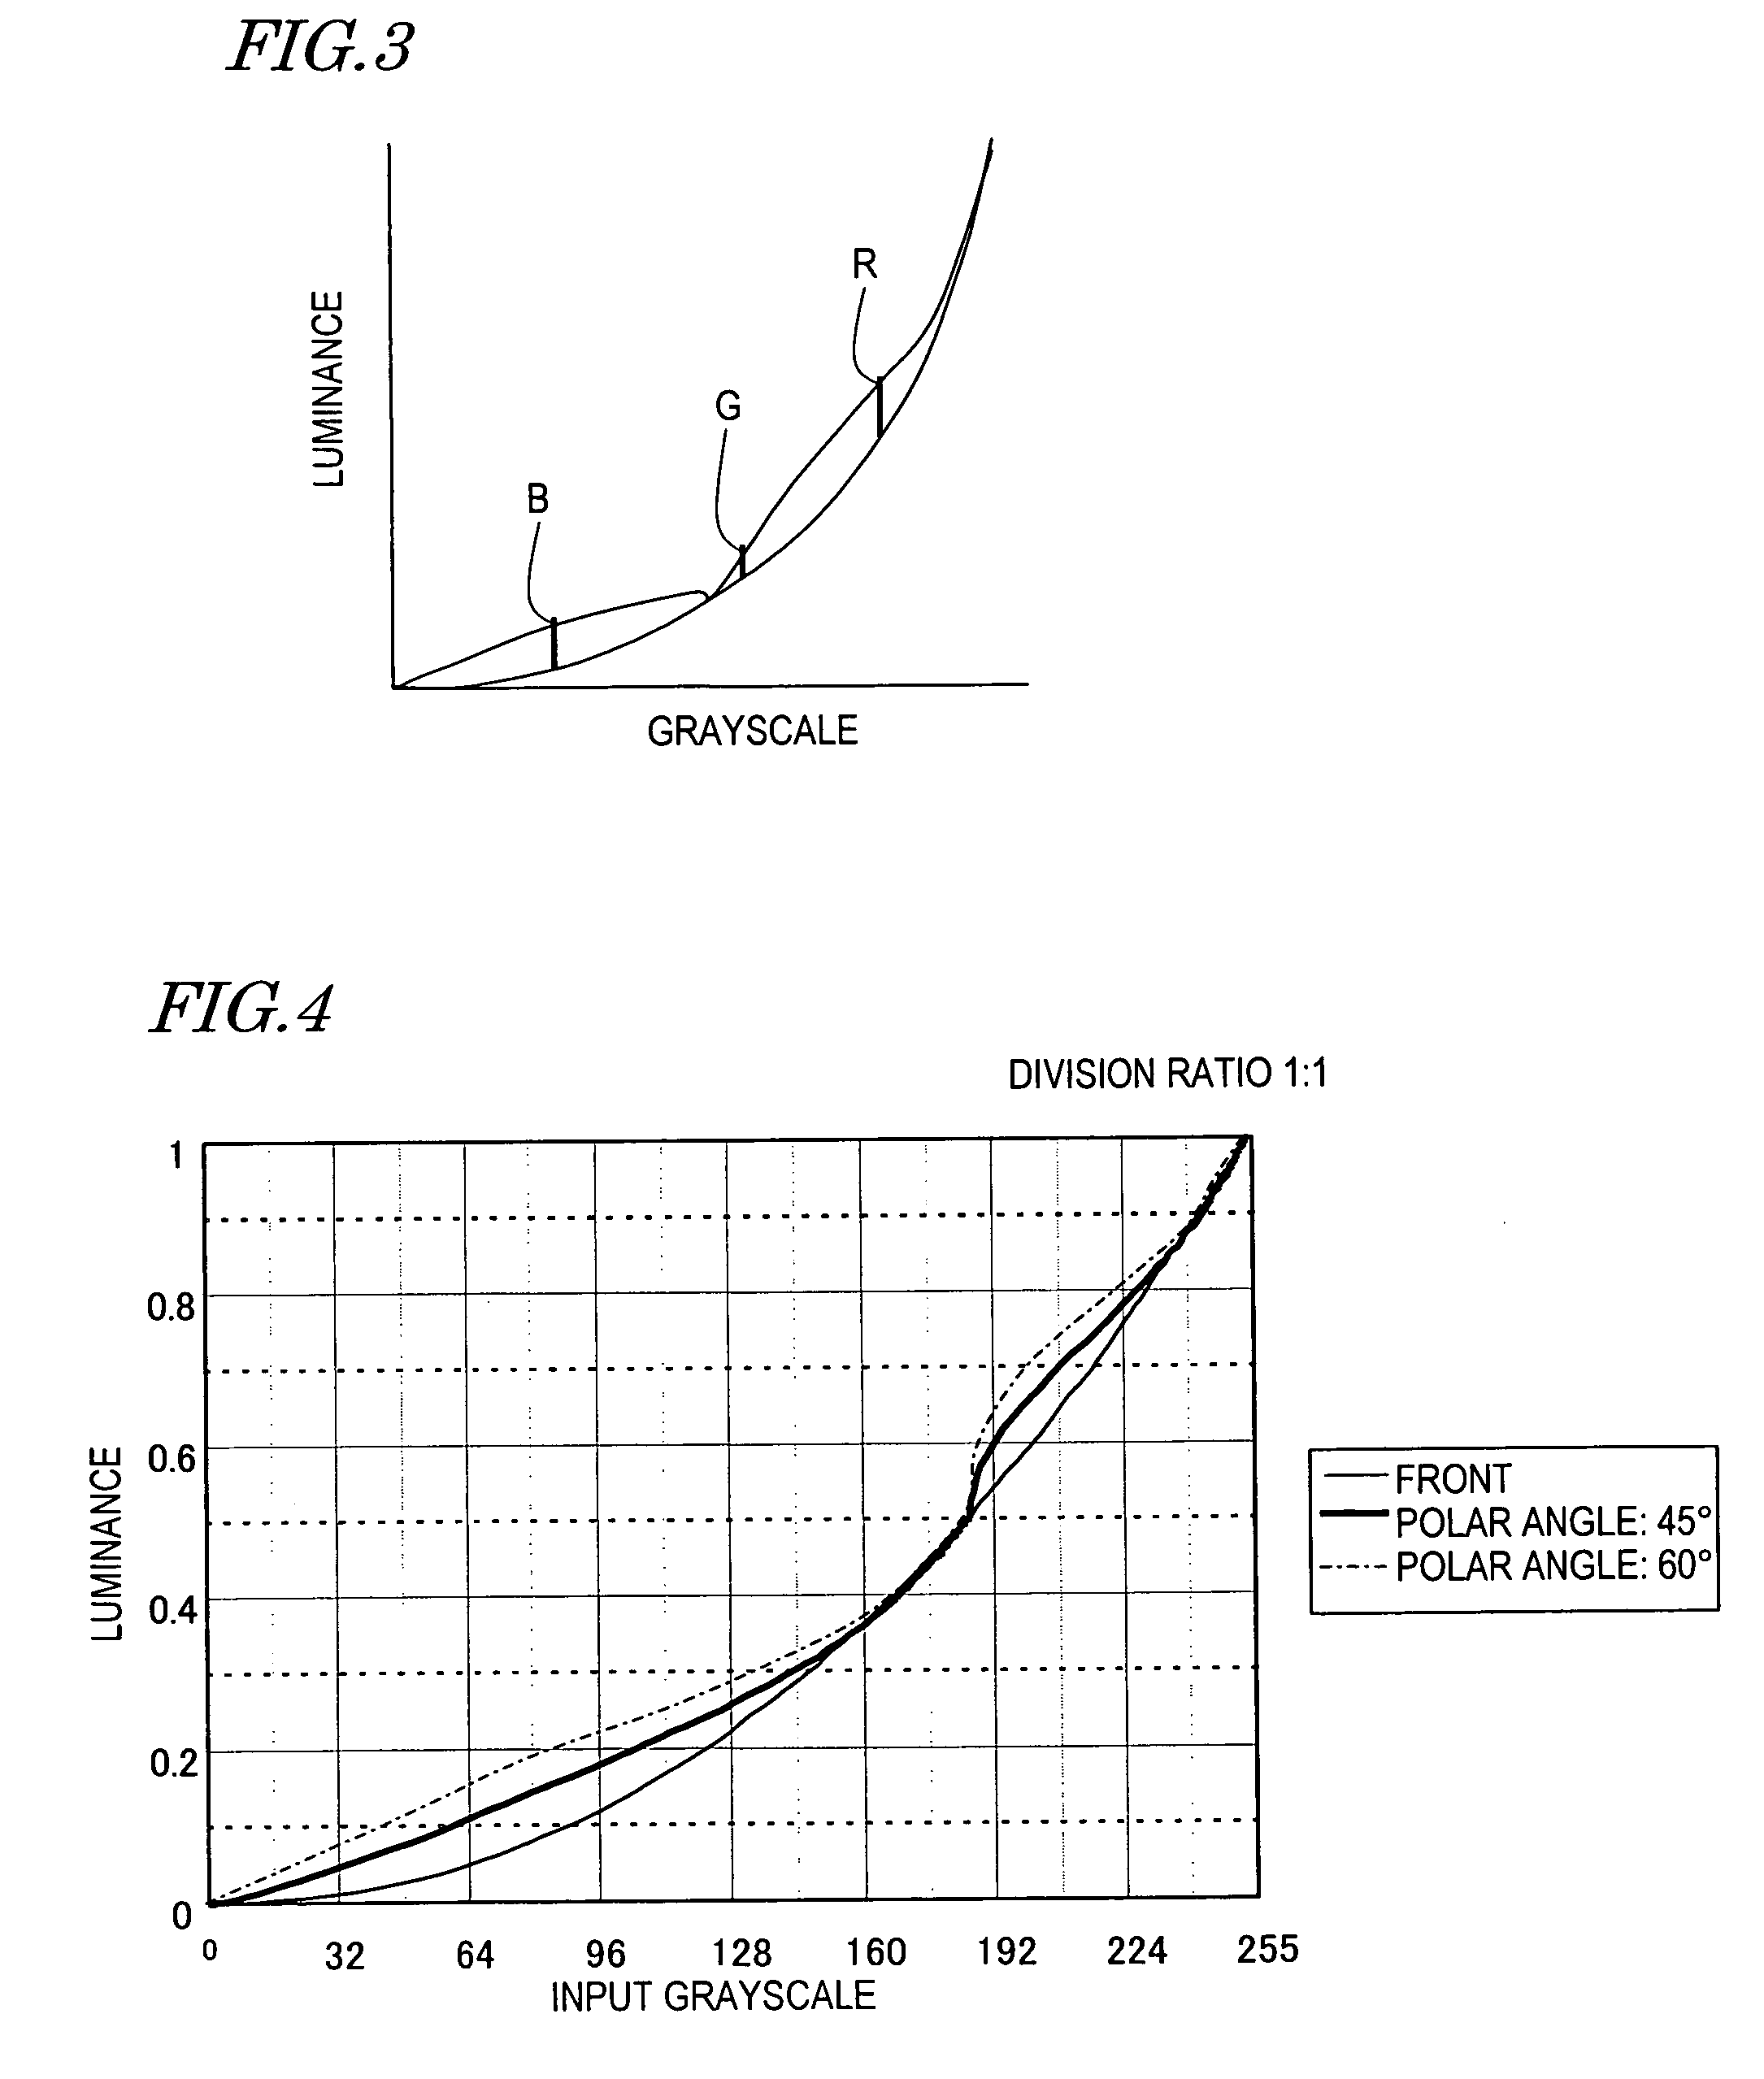
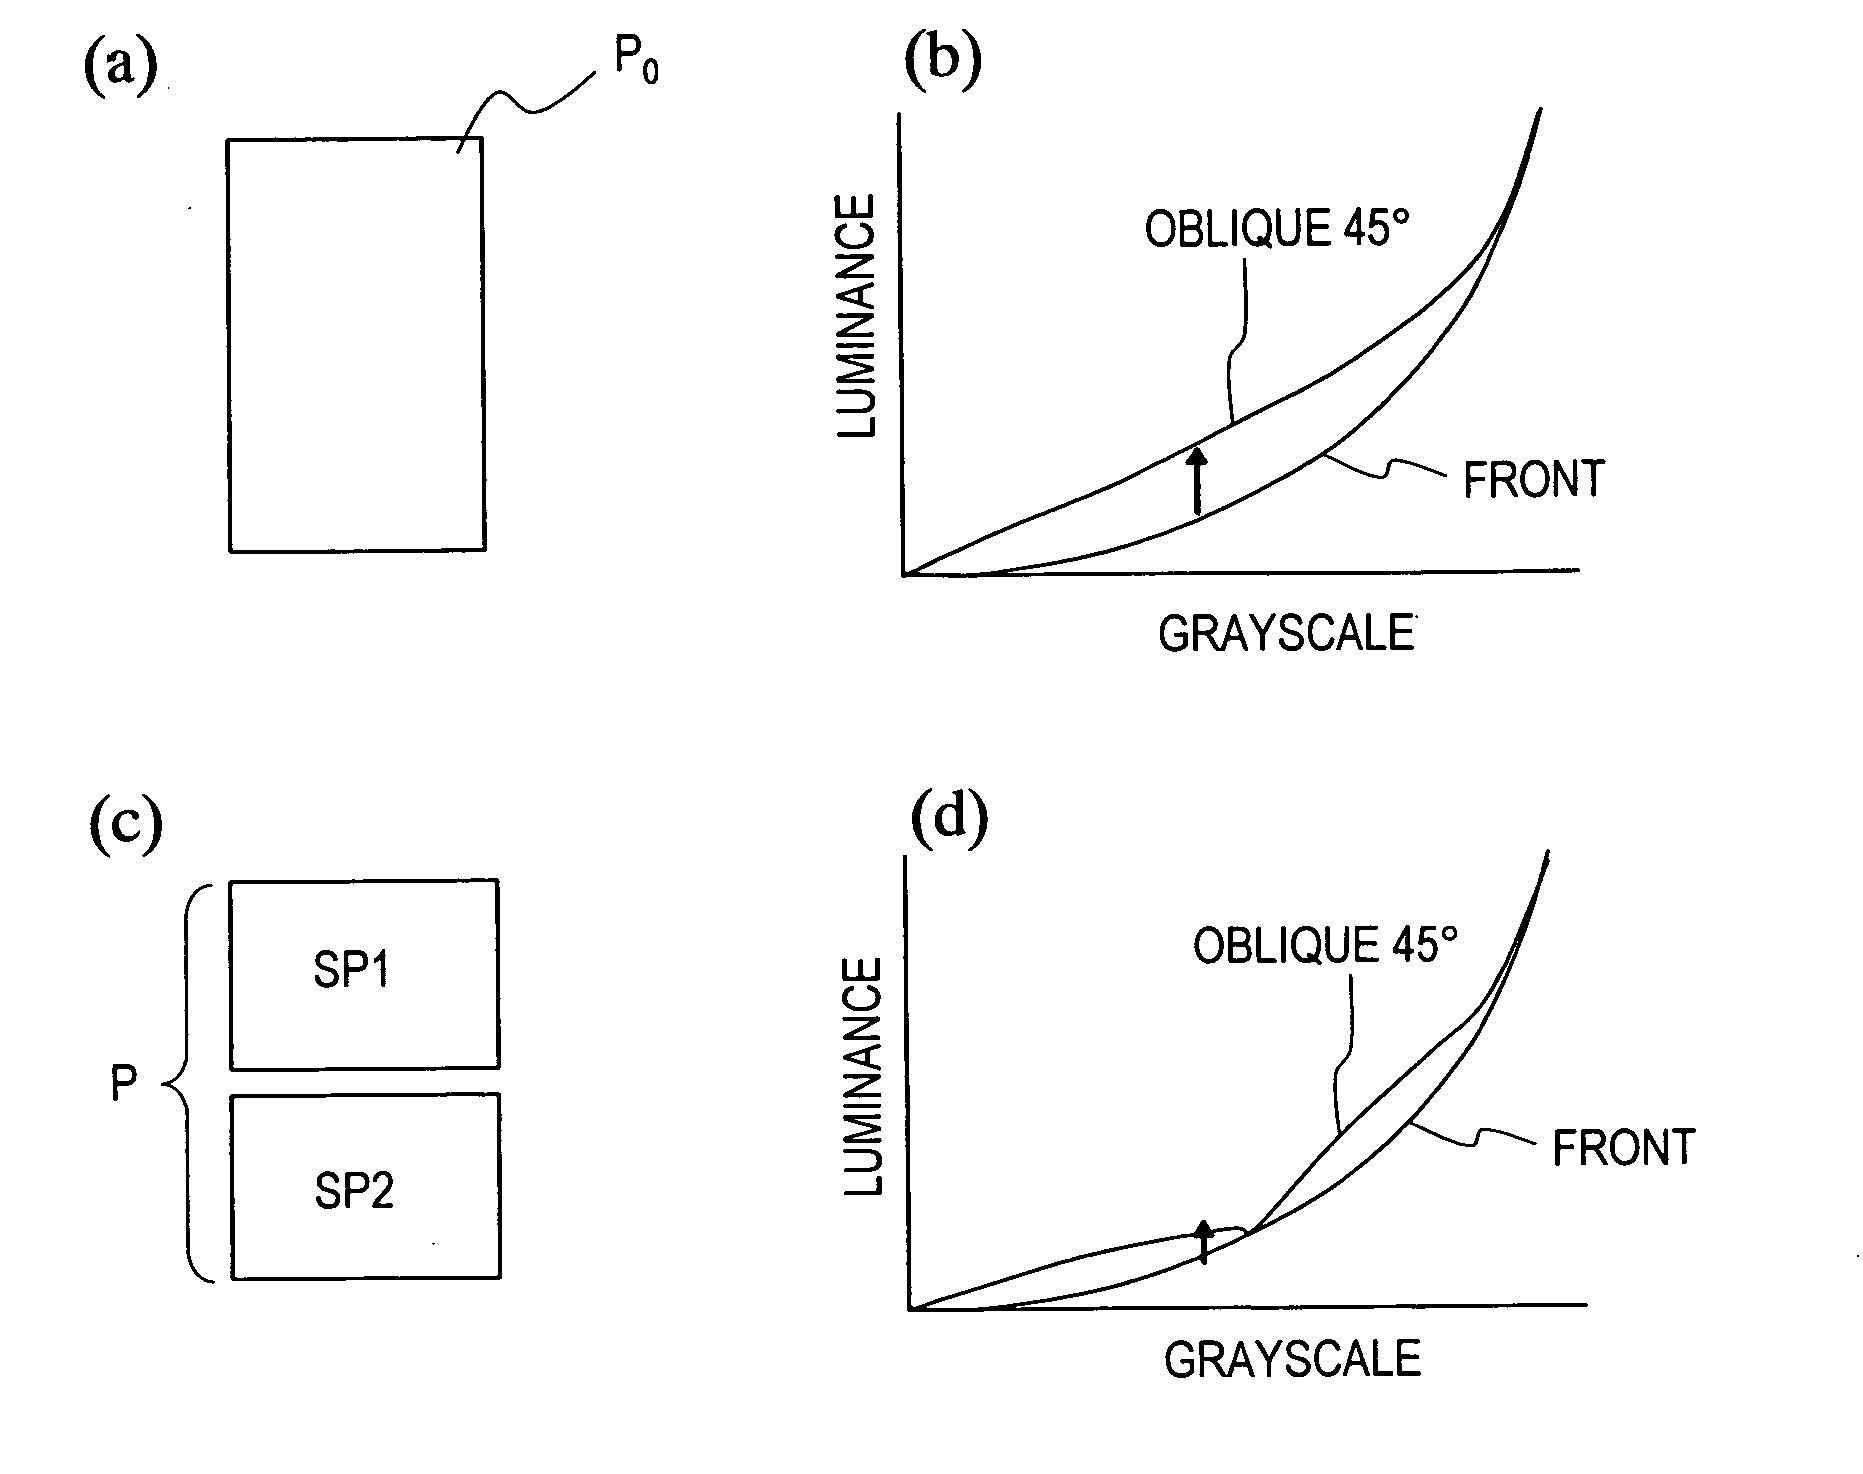
A liquid crystal display device includes a plurality of pixels each connected to a signal line via a switching element. Each pixel includes first and second sub-pixels having voltage vs. luminance characteristics different from each other with respect to a signal voltage supplied from the signal line. A threshold signal voltage of the first sub-pixel is lower than that of the second sub-pixel. The pixels form color display pixels which are red, green pixel and blue pixels. Where the area ratio of the first sub-pixel in each of the red, green and blue pixels is SR1, SG1 and SB1, and the ratio of the lighting-up time period of the first sub-pixel of each of the red, green and blue pixels in one vertical scanning period is TR1, TG1 and TB1, the relationship of (SR1×TR1)>(SG1×TG1)>(SB1×TB1) holds.
Owner:SHARP KK
Edge exposing apparatus
ActiveUS20050062951A1Avoid quality lossReduce delaysSemiconductor/solid-state device manufacturingPhotomechanical exposure apparatusLuminous intensityEffect light
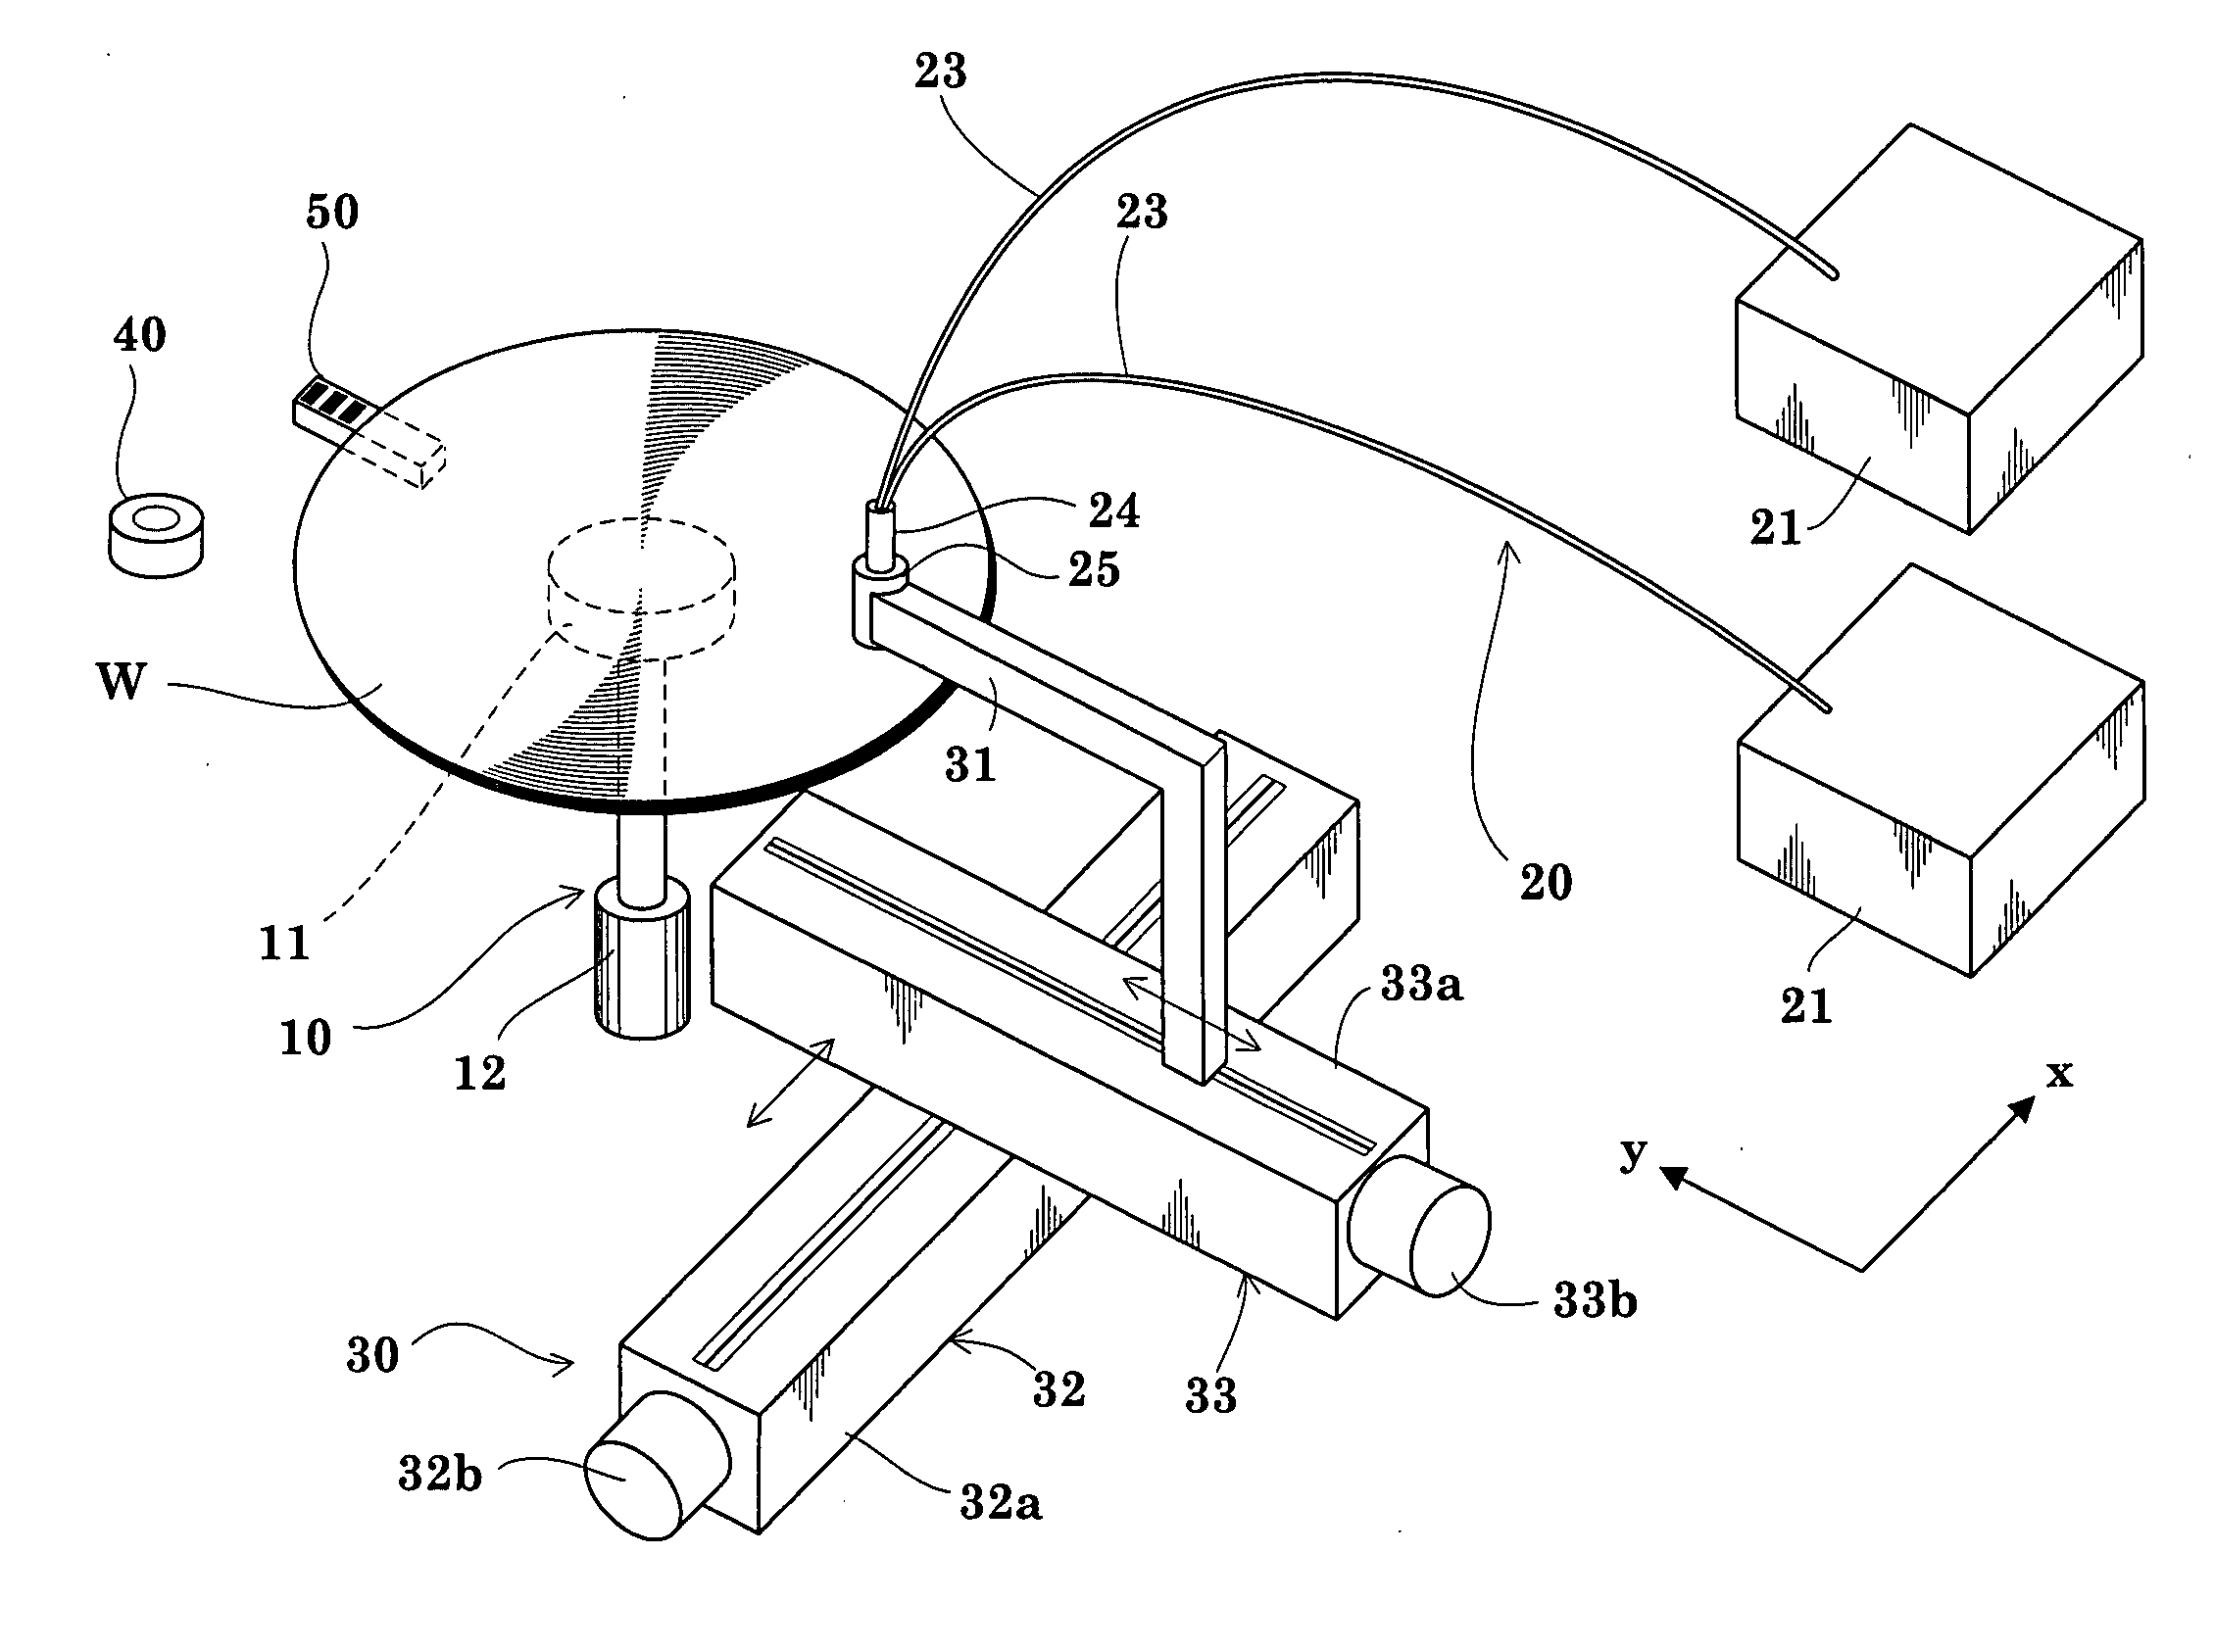
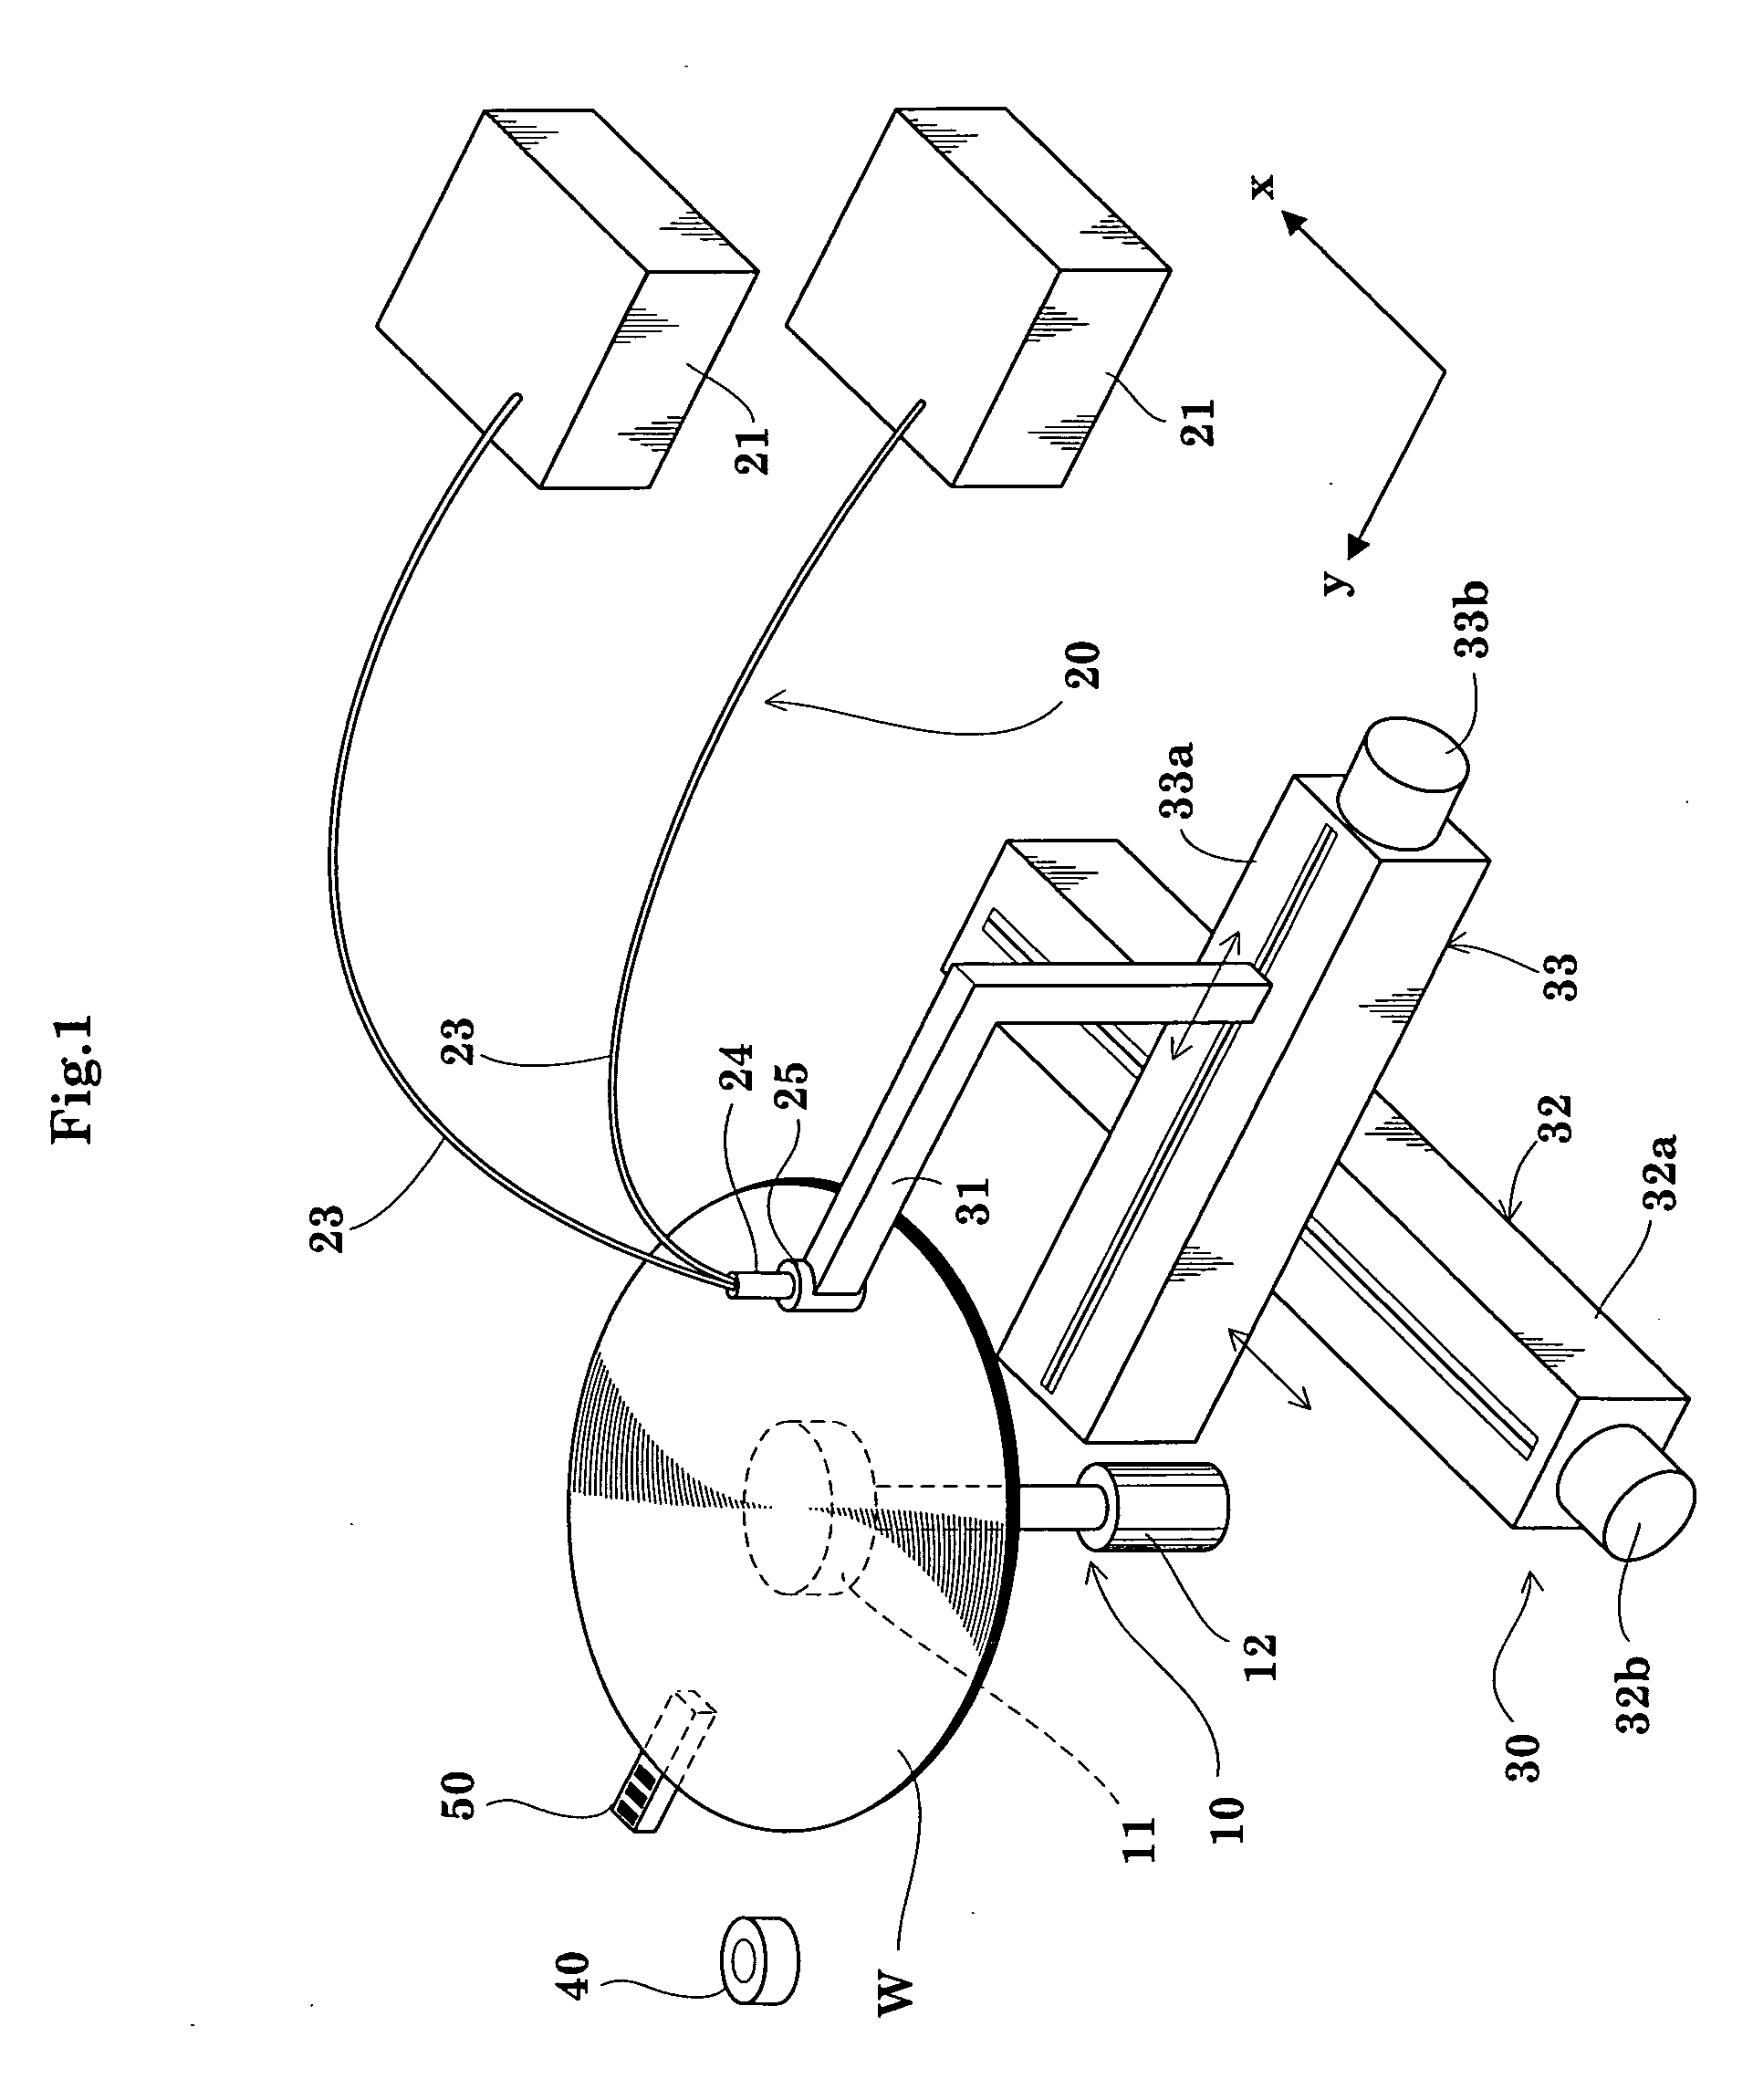
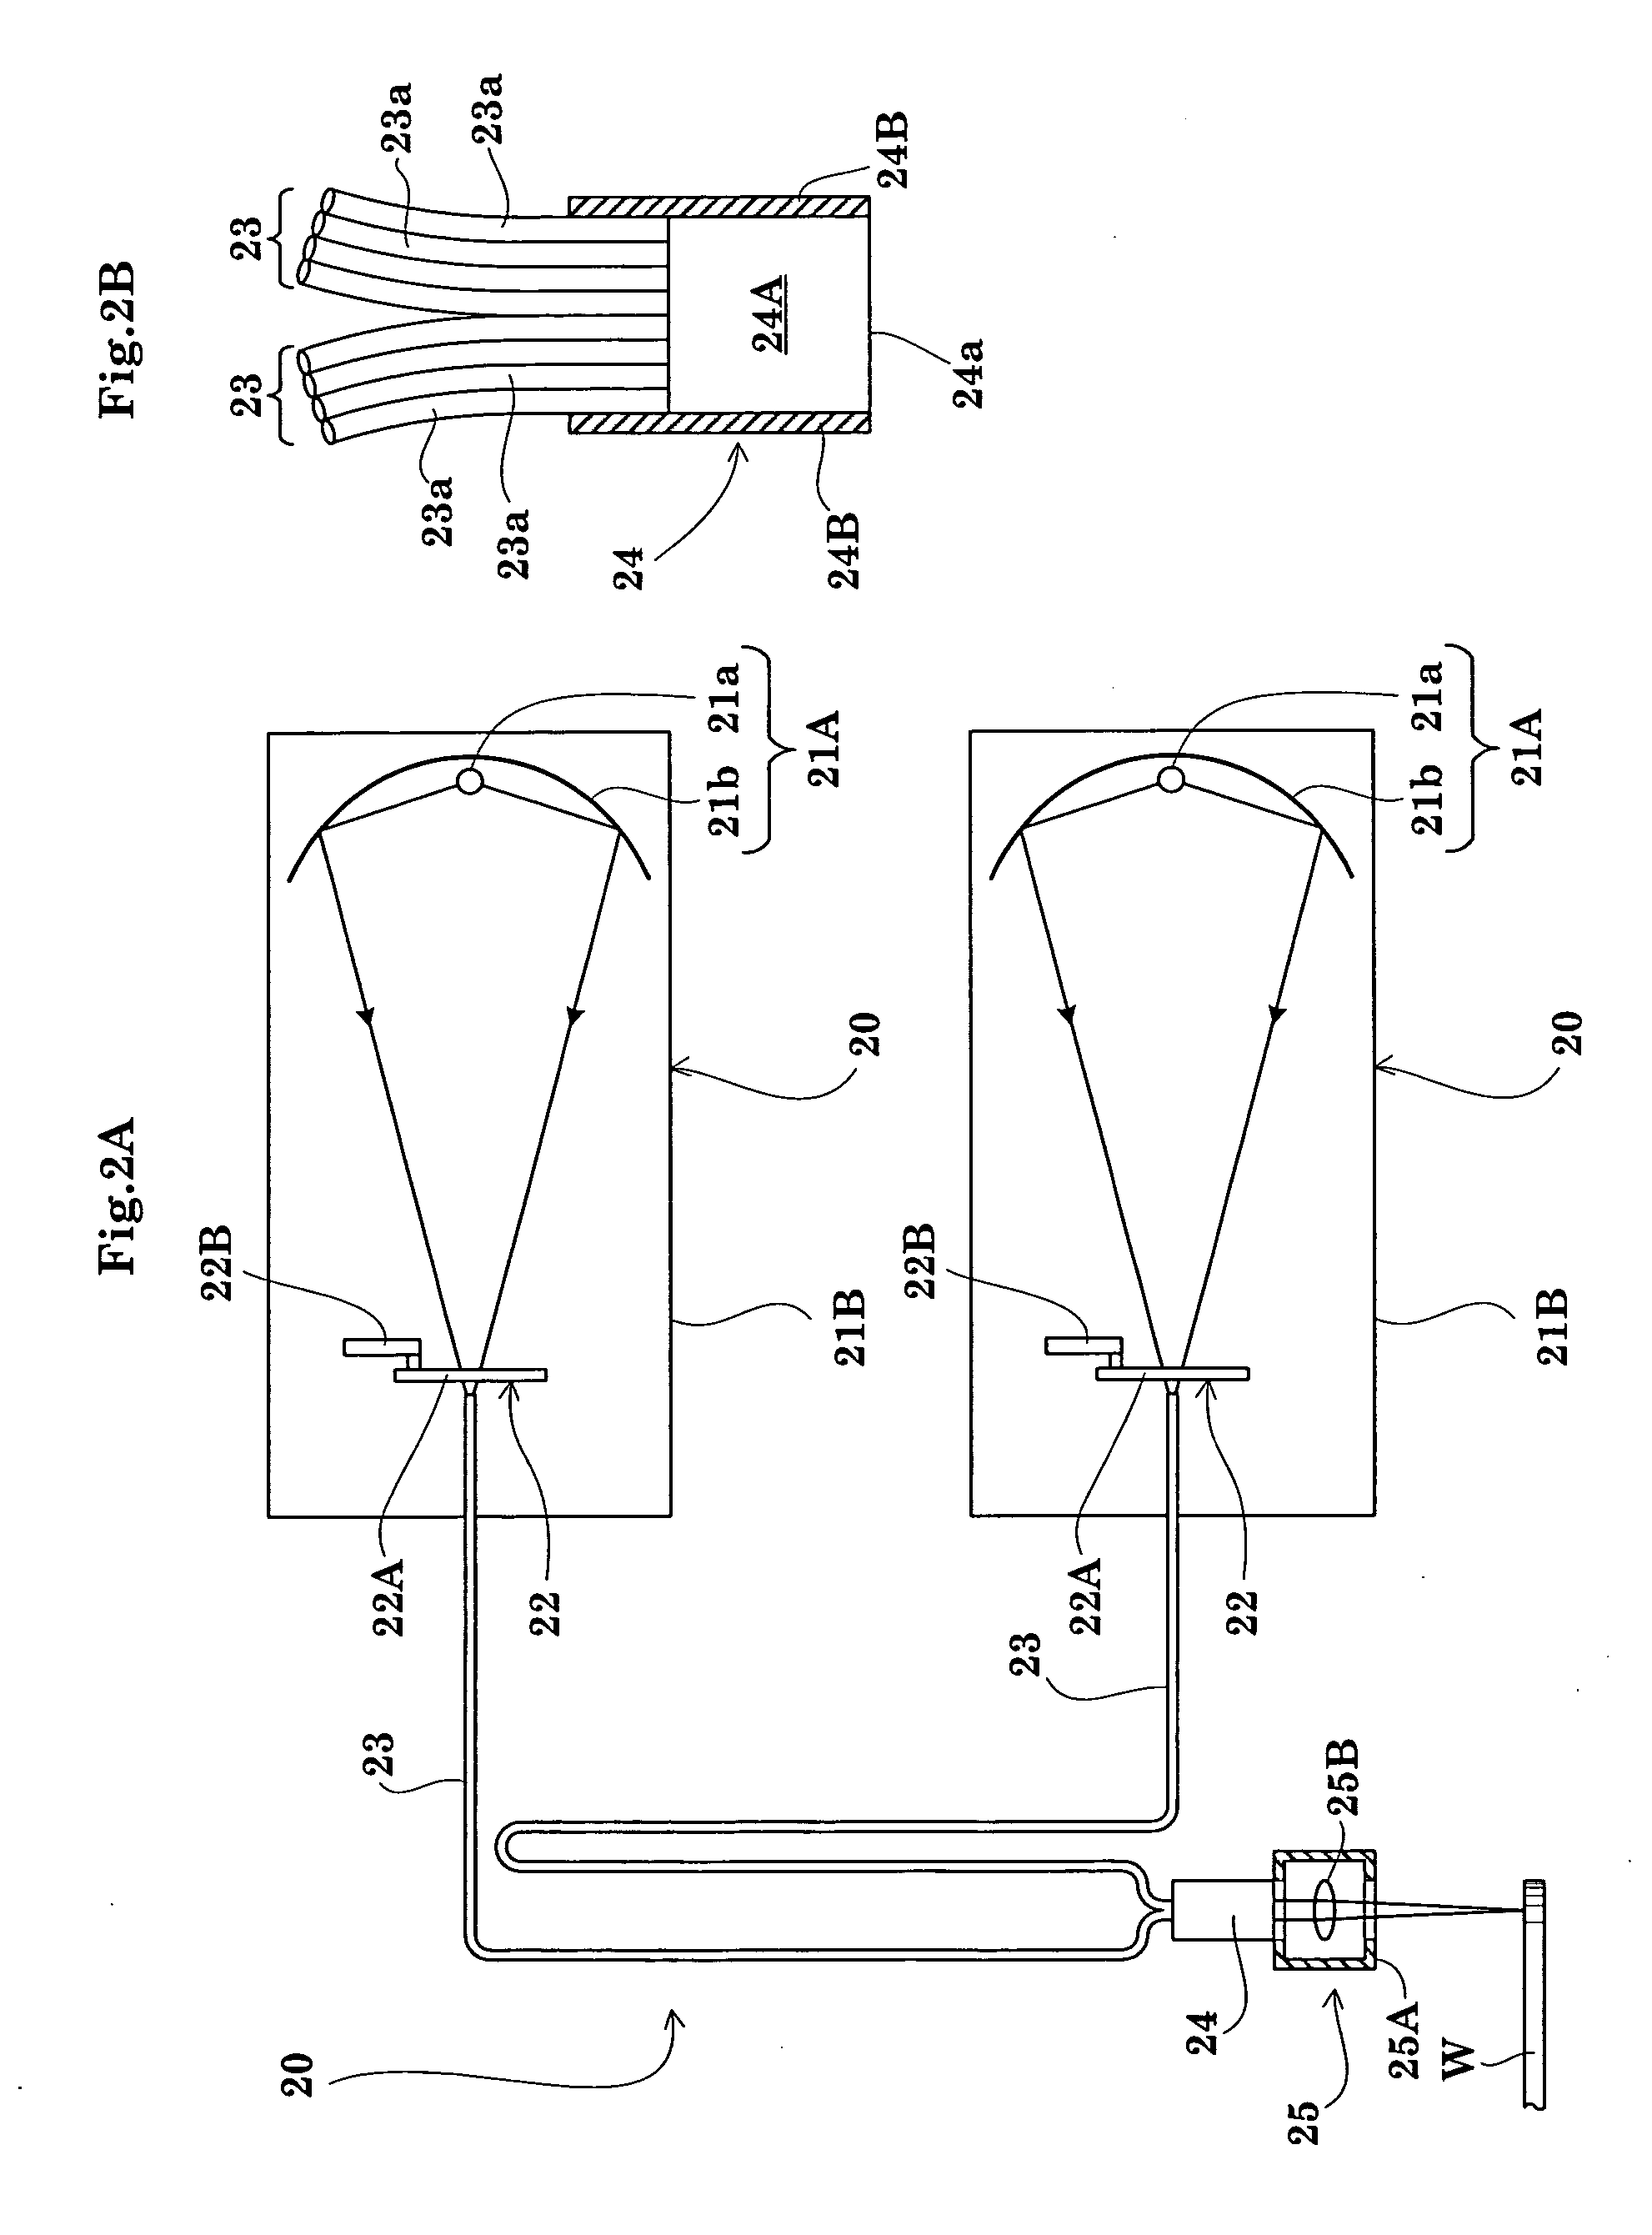
An edge exposing apparatus includes a photo detector and a lighting time measuring circuit for detecting a decrease in performance of light source units. The same lighting time measuring circuit has a function to detect a ready state (i.e. stabilization of luminous intensity) of the light source units capable of performing edge exposure. When the lighting time measuring circuit detects a lighting time having reached a preset value, or when the photo detector detects a luminous intensity below a preset value, the light source units are determined to have lowered in performance, and are switched off. The lighting time measuring circuit measures a lighting time from a startup (switch-on) of the light source units, and when the lighting time reaches a preset value, the light source units are determined to have attained the ready state and edge exposure is started with the light source units. When a decrease in performance is detected, one light source unit is started while continuing edge exposure with the other light source unit. When a ready state is detected, the edge exposure with the light source unit is terminated (switch-off), and edge exposure is performed with the light source unit having attained the ready state.
Owner:SCREEN SEMICON SOLUTIONS CO LTD
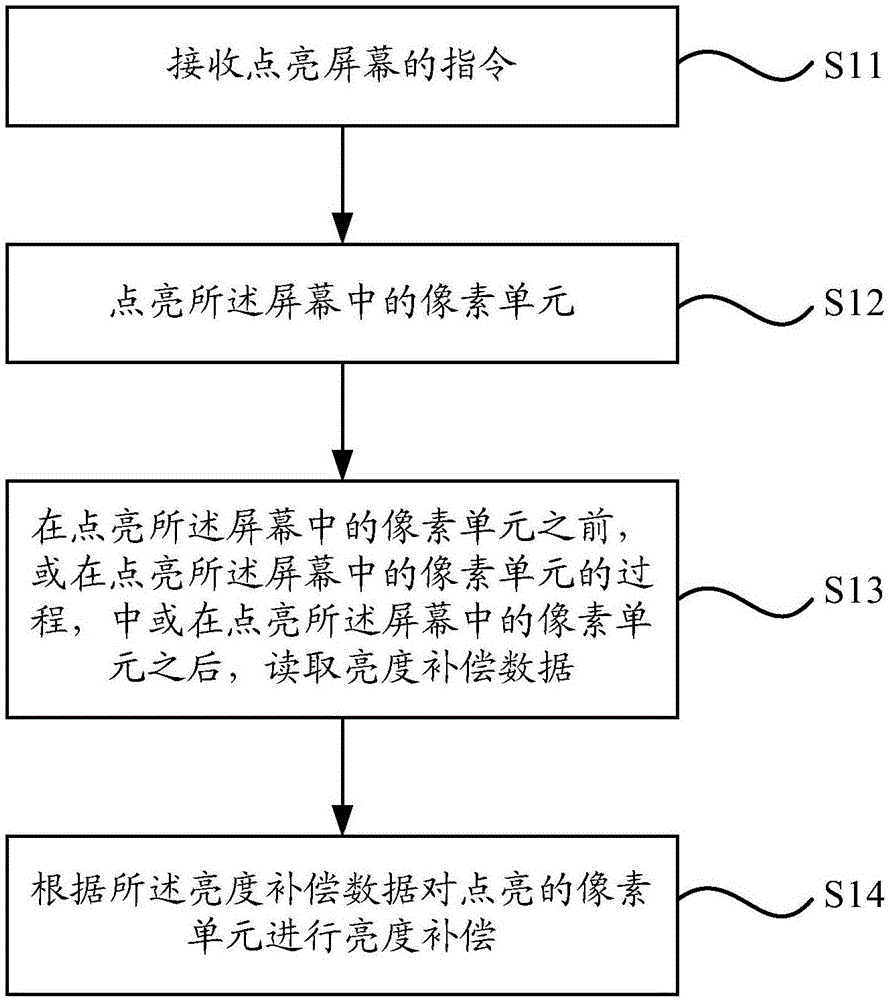
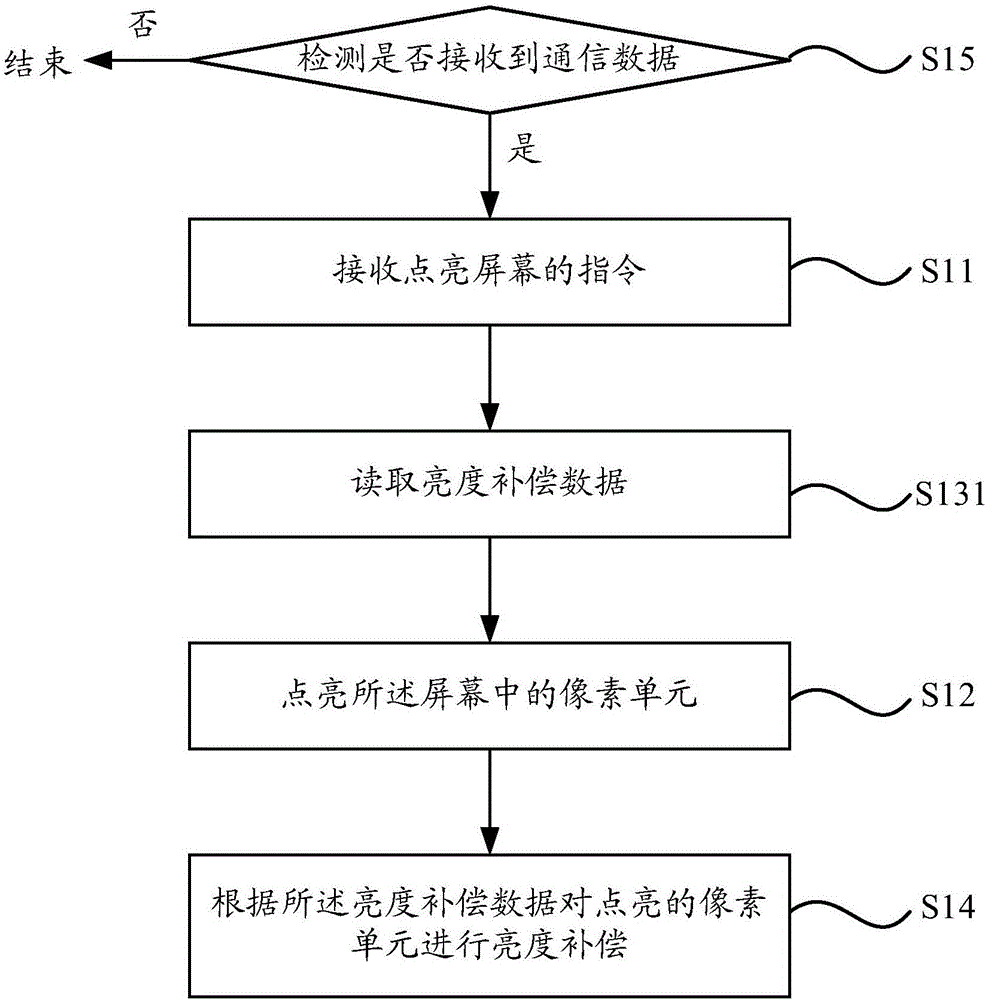
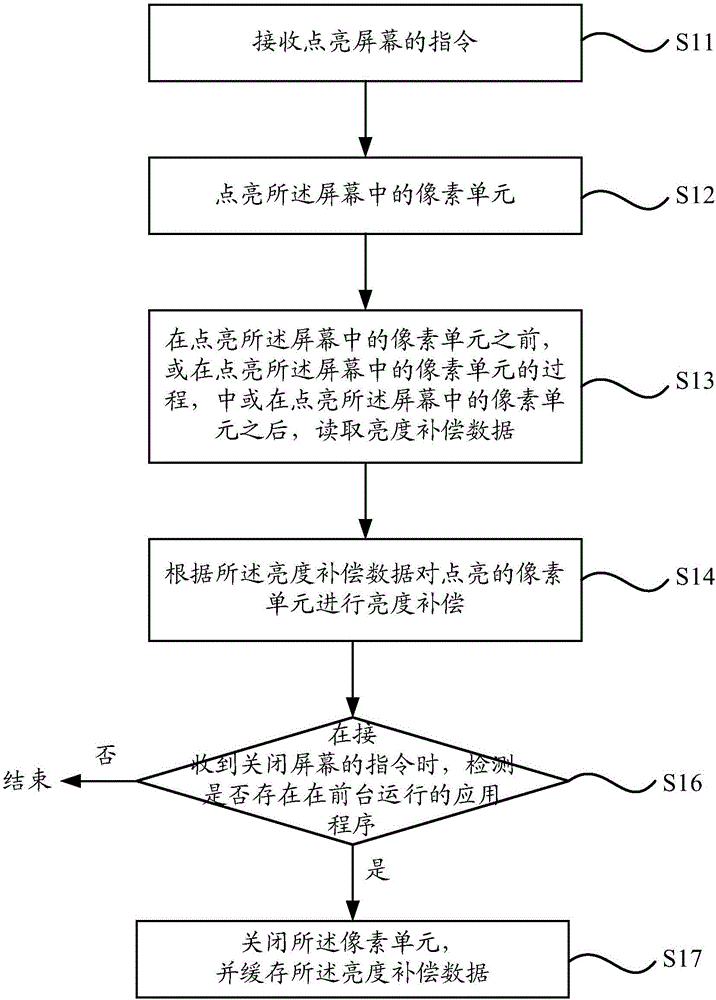
Brightness compensation method, brightness compensation device and electronic equipment
Owner:BEIJING XIAOMI MOBILE SOFTWARE CO LTD
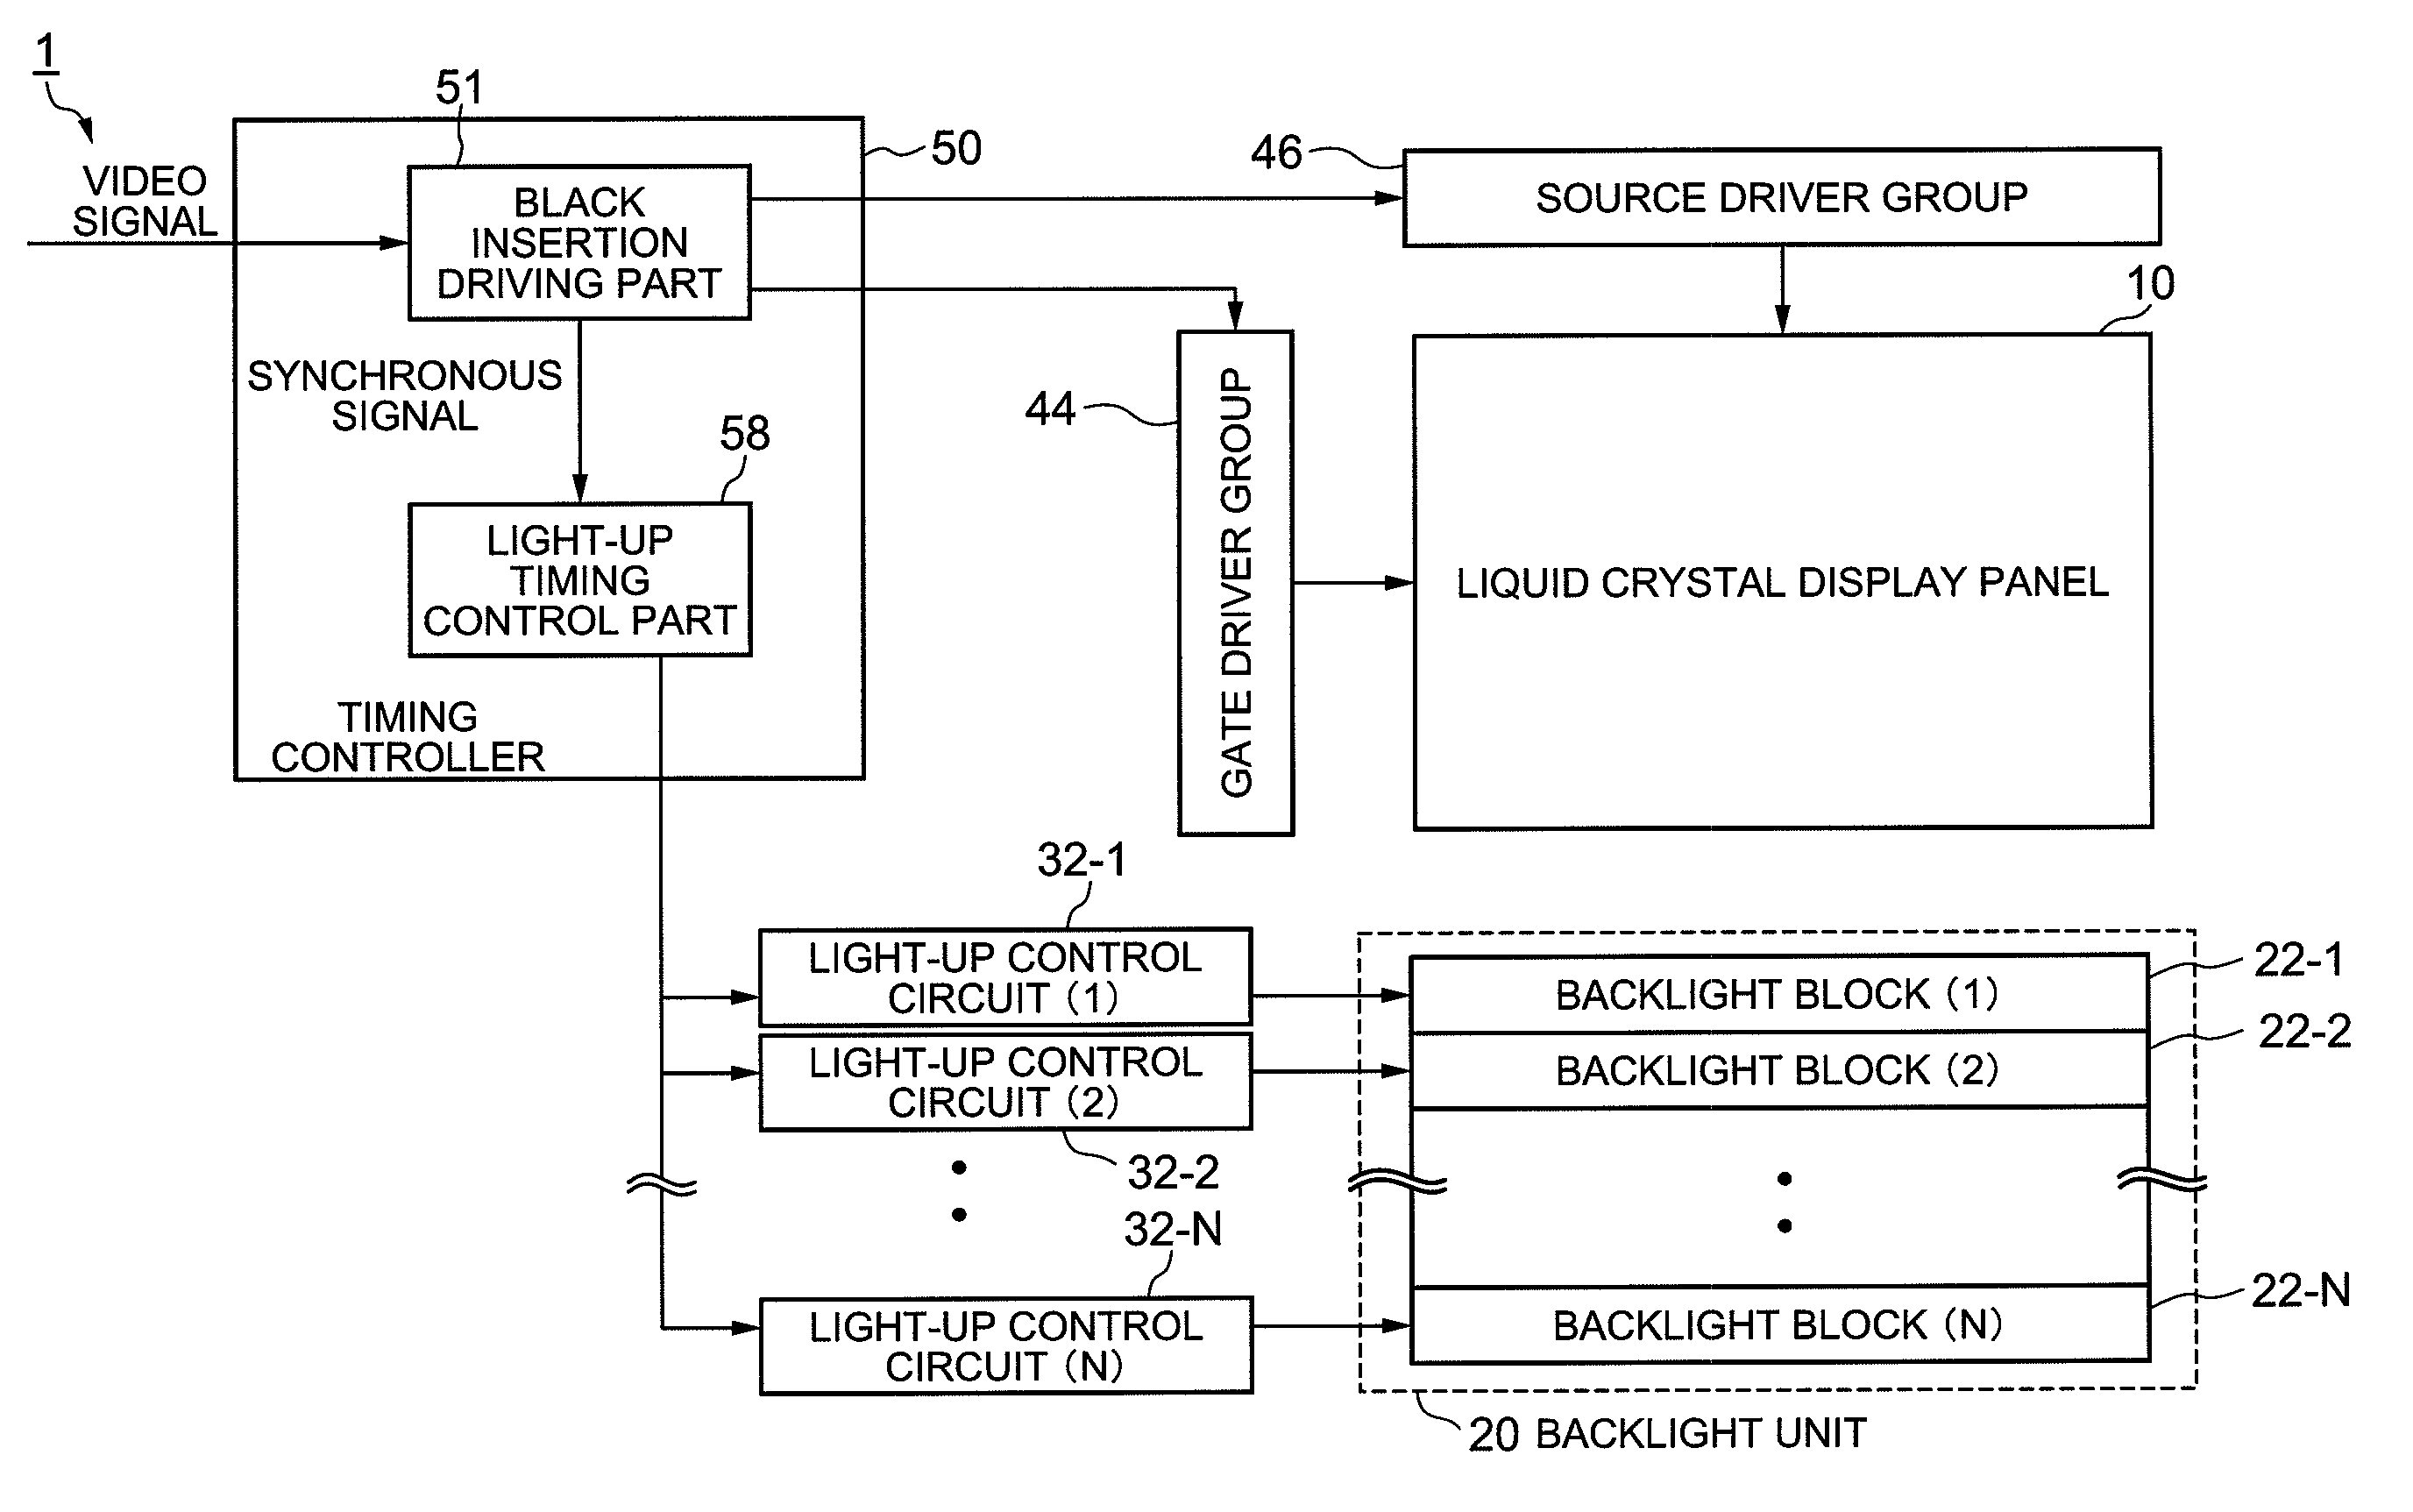
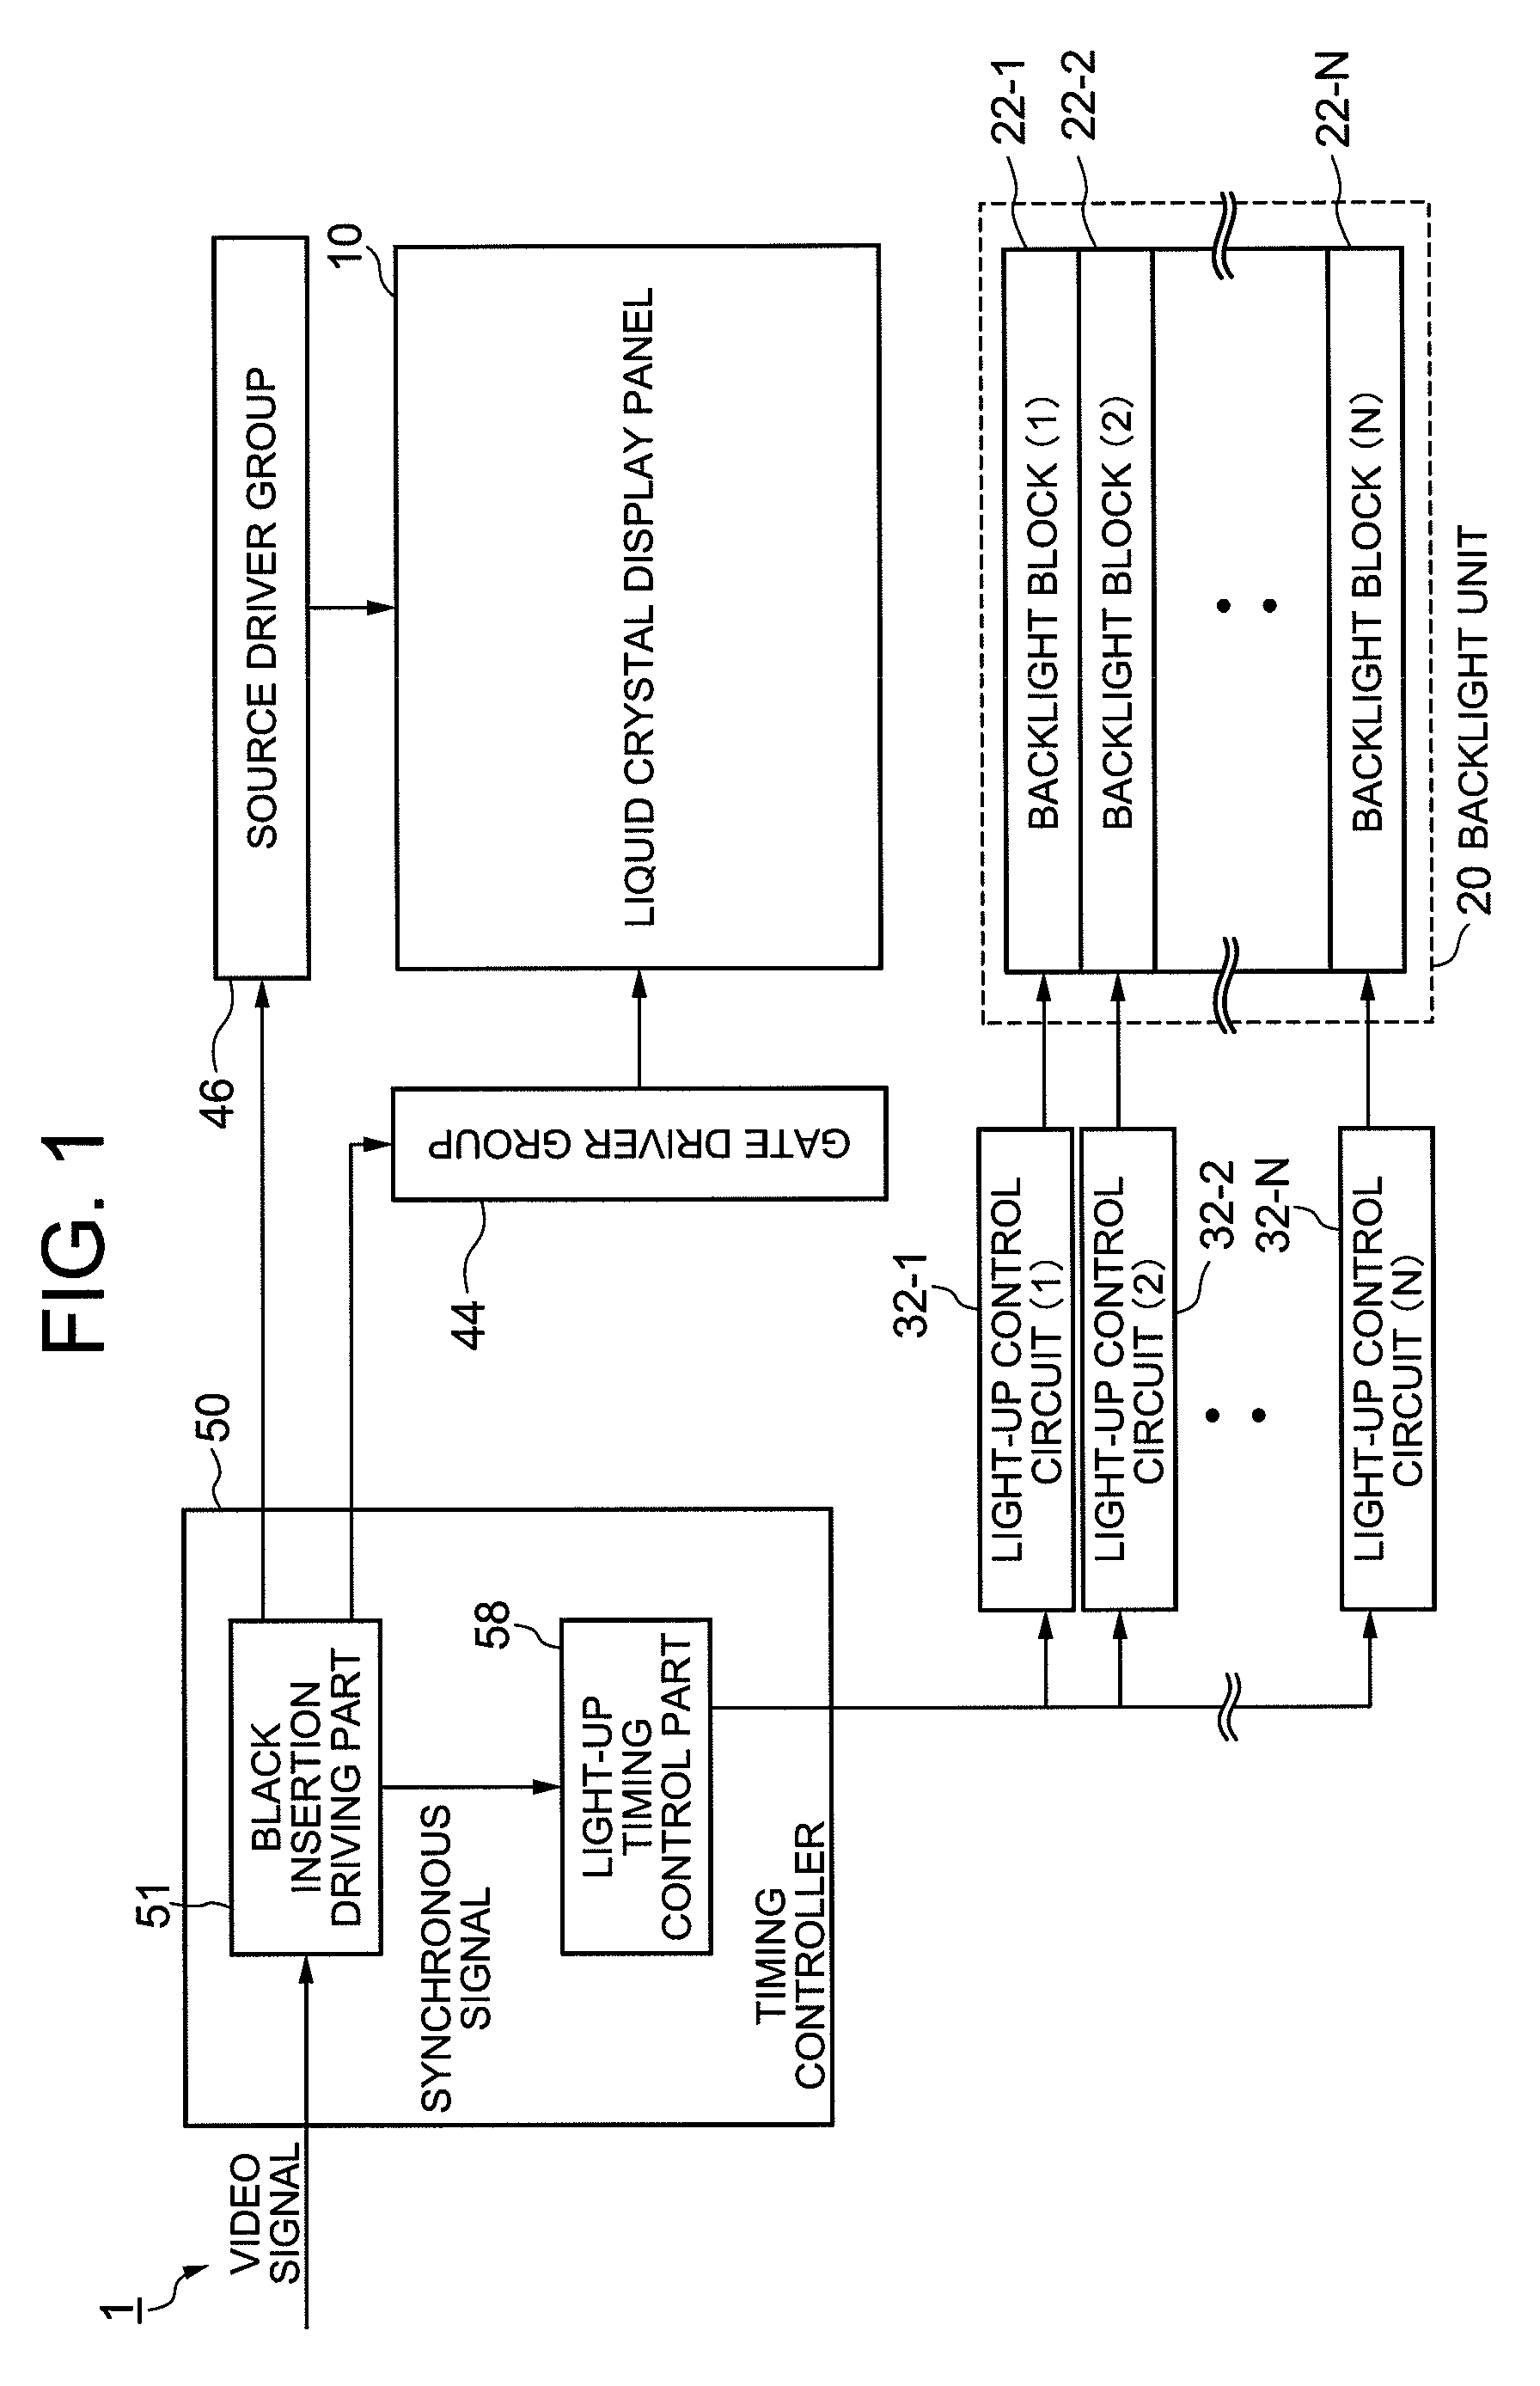
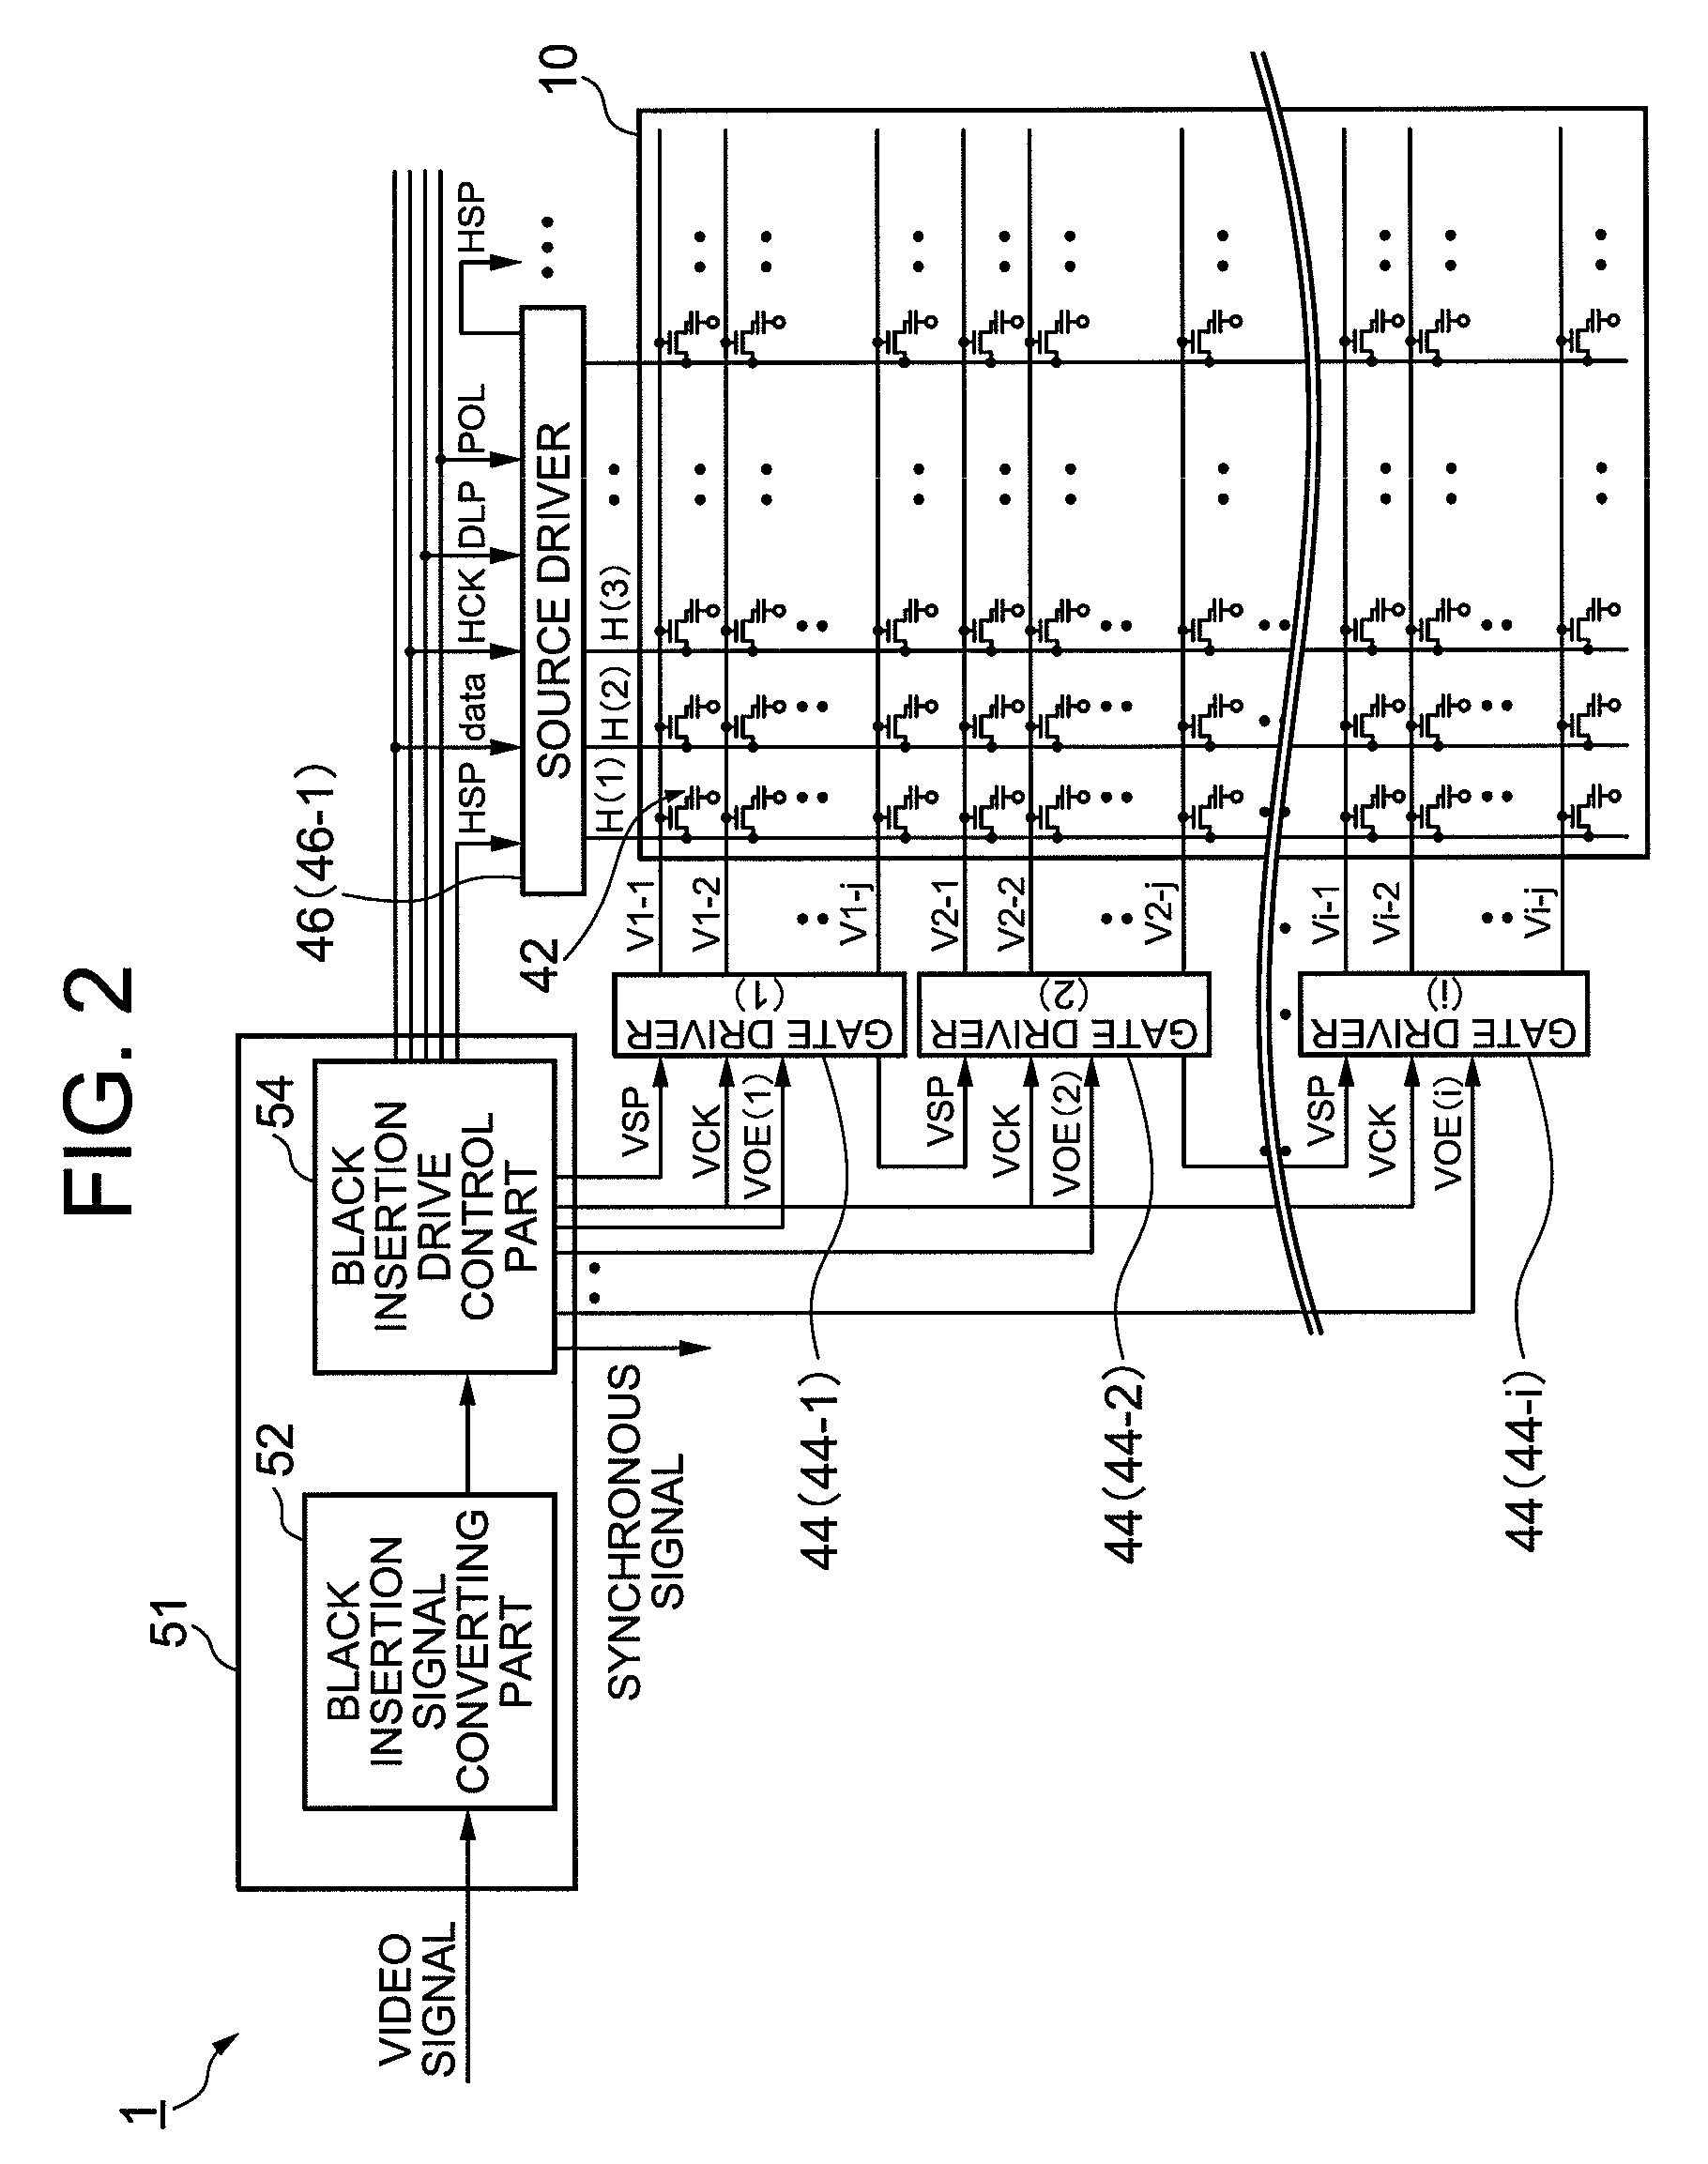
Display panel control device, liquid crystal display device, electronic apparatus, and display panel drive control device
ActiveUS8264451B2Increase the gapReduce the numberCathode-ray tube indicatorsInput/output processes for data processingStart timeLiquid-crystal display
Owner:HANNSTAR DISPLAY CORPORATION
Color sequential liquid crystal display and liquid crystal display panel driving method thereof
InactiveUS20100013755A1Reduce scan timeExtension of timeStatic indicating devicesLighting-up timeMonochromatic color
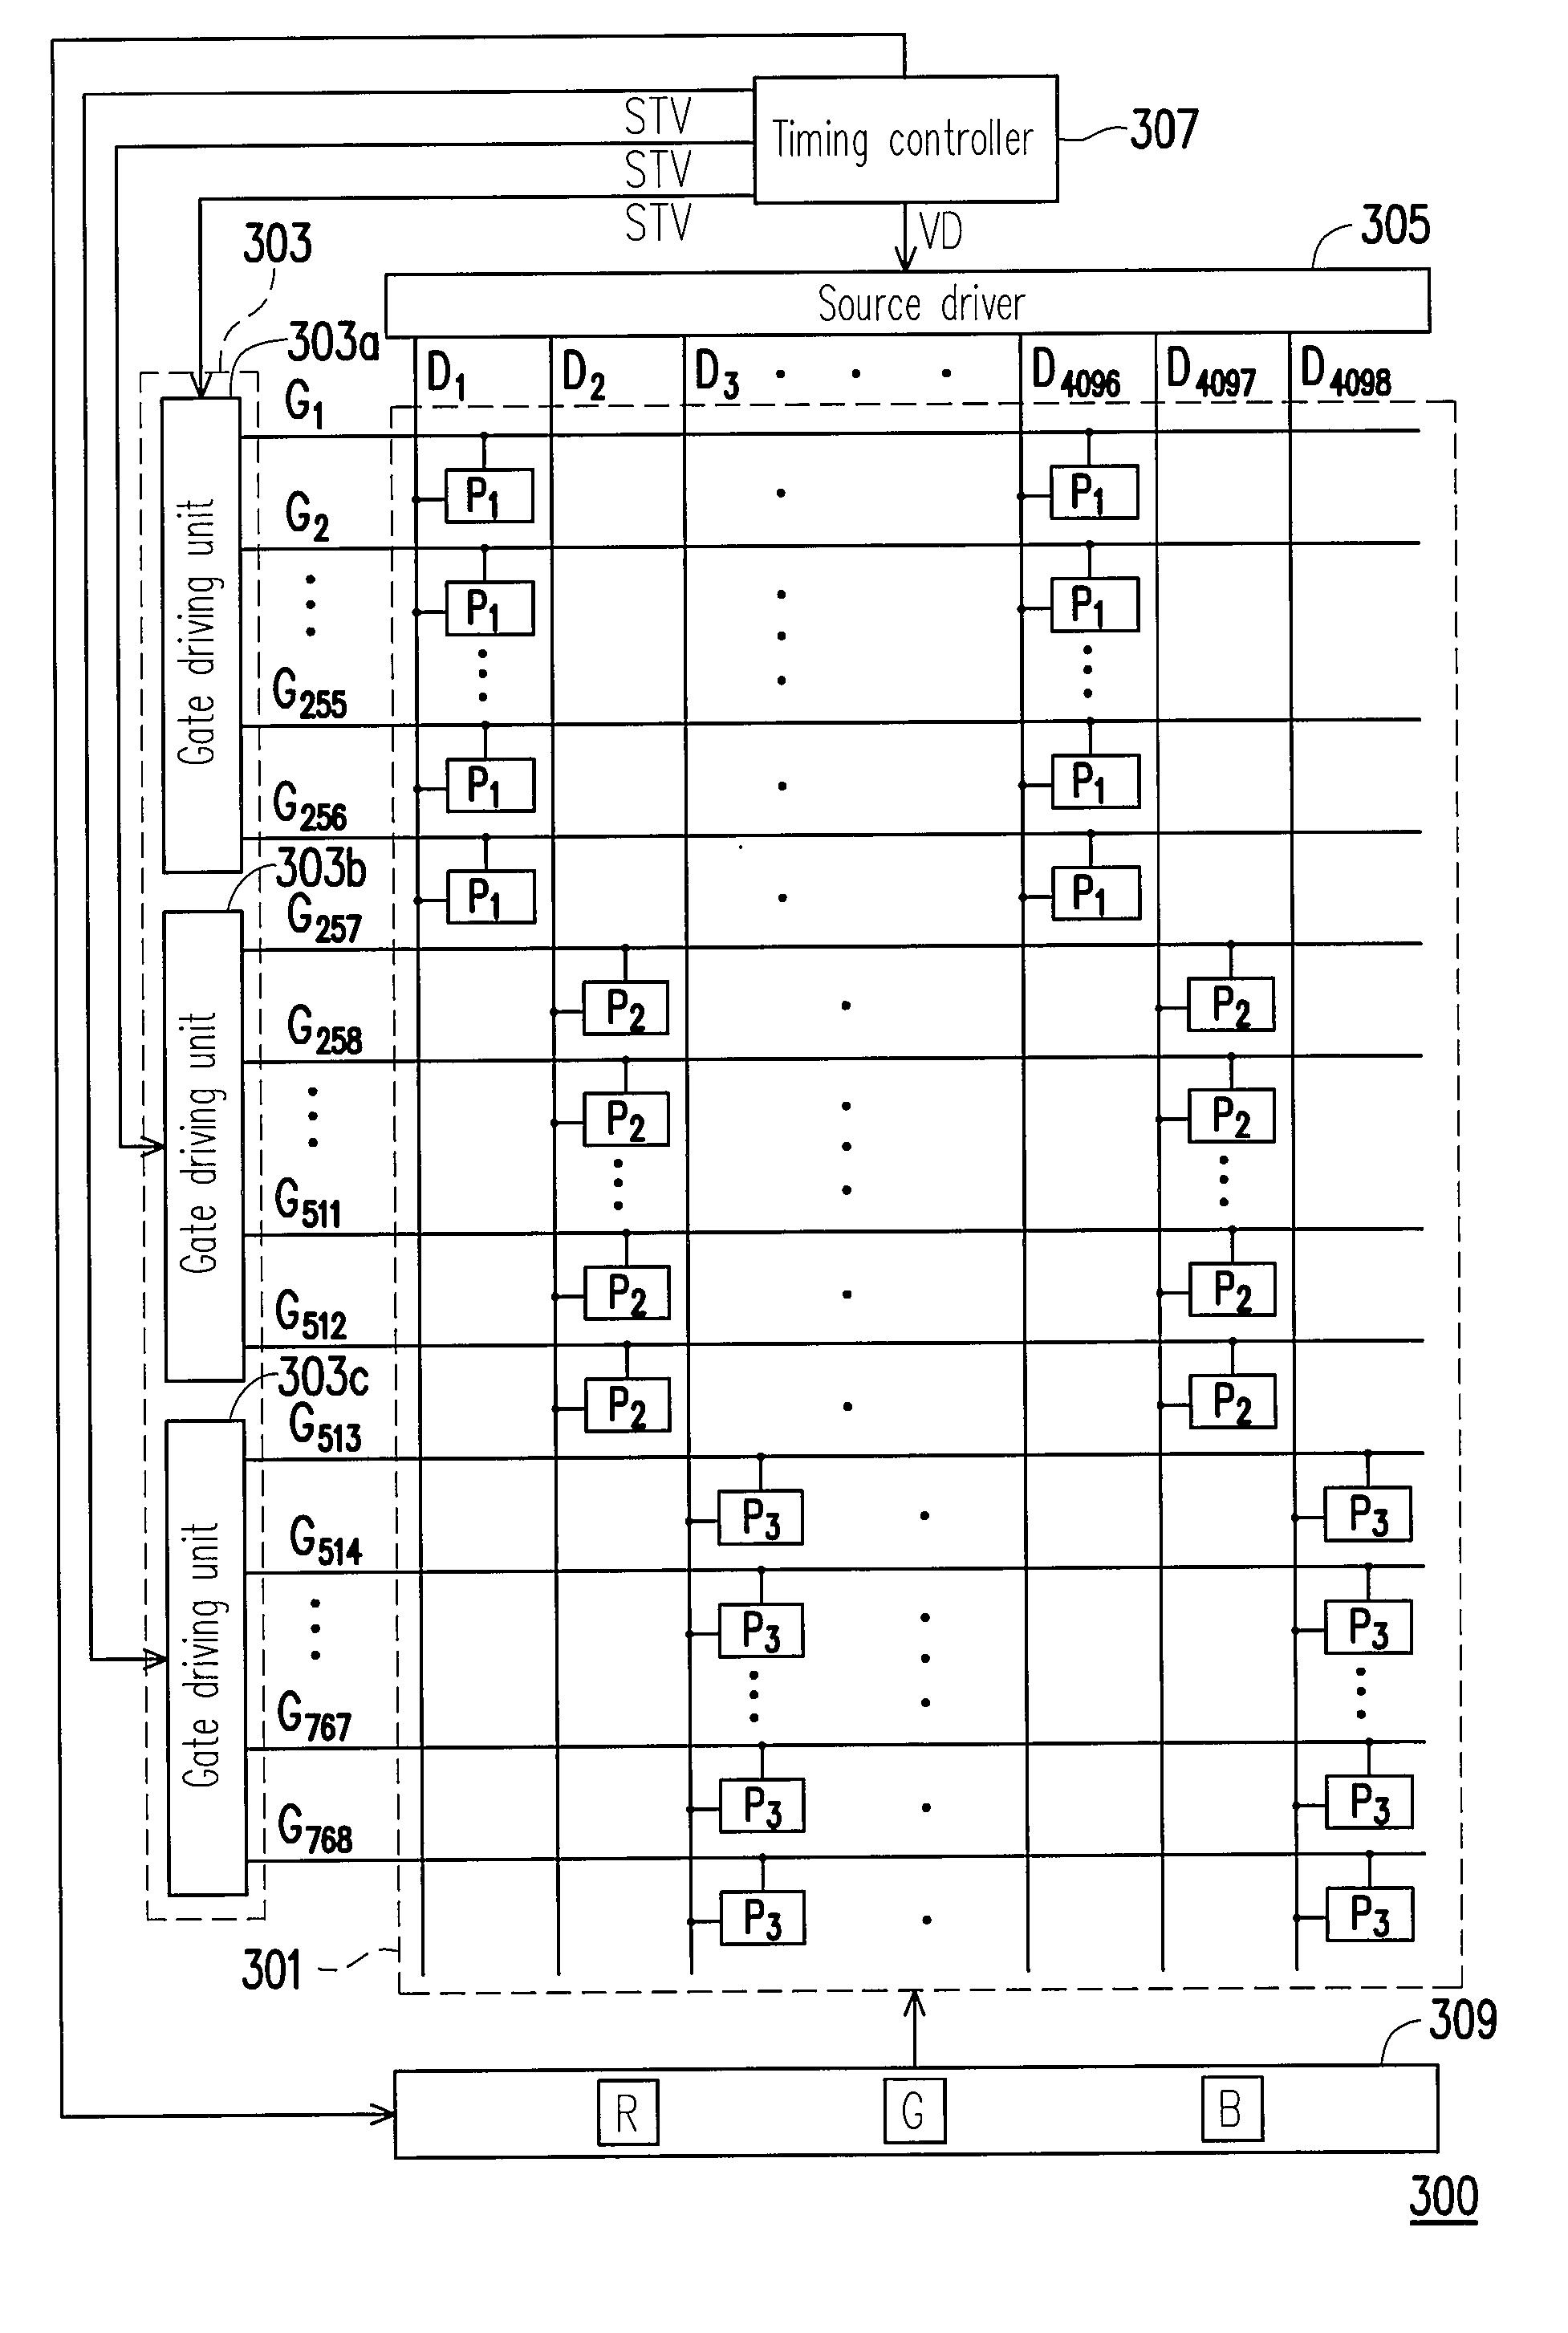
A color sequential liquid crystal display (color-sequential-LCD) and an LCD panel driving method thereof are disclosed. By changing the arrangement of the pixel array in the LCD panel and turning on several rows of pixels in the LCD panel at the same time, so that the color sequential LCD of the present invention not only respectively reduces the scanning time of red, green and blue video data to make the liquid crystal molecules of all the pixels on the LCD panel have enough response time but also respectively increases the lighting-up time of the red, green and blue light emitting diodes of the back light module to promote the display brightness of the entire LCD panel. Therefore, the color sequential LCD of the present invention displays a single color or a full color image without the bottom color mixing phenomenon, and furthermore, the display brightness thereof can be promoted.
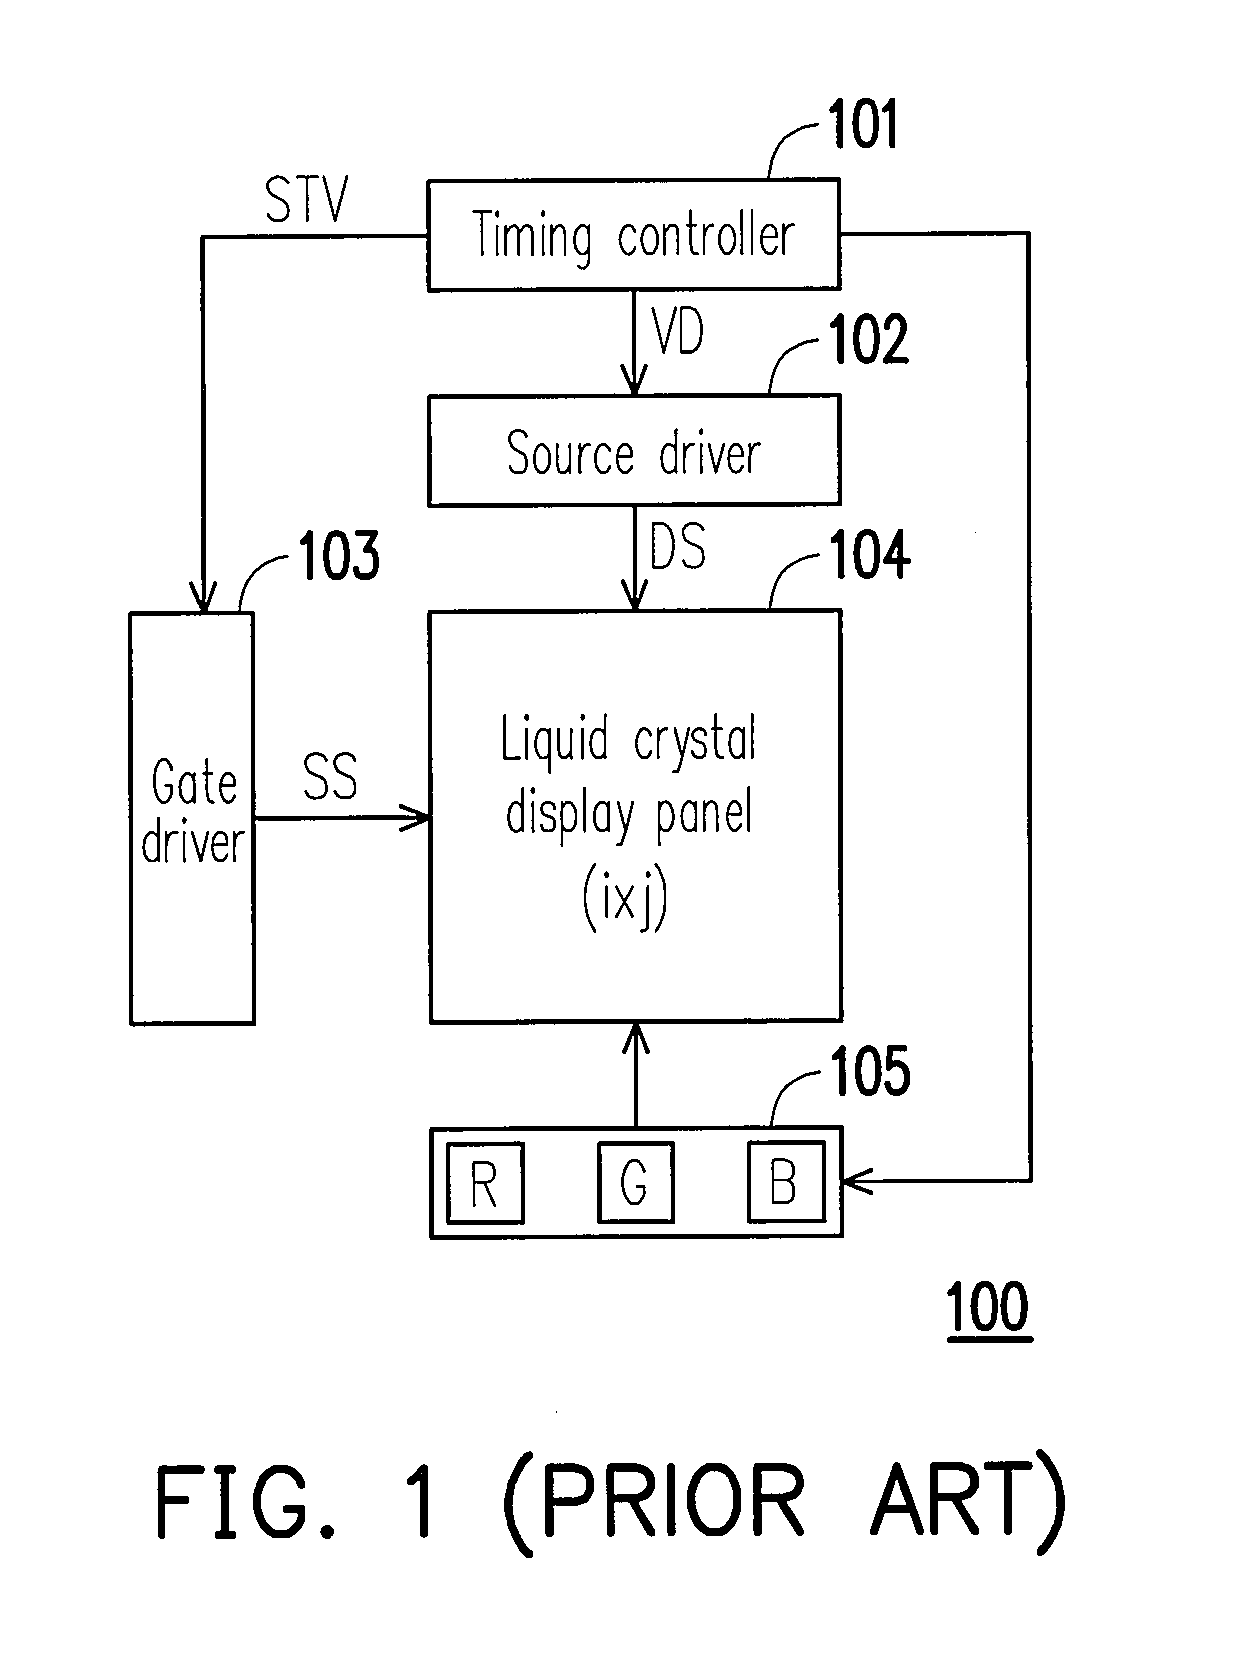
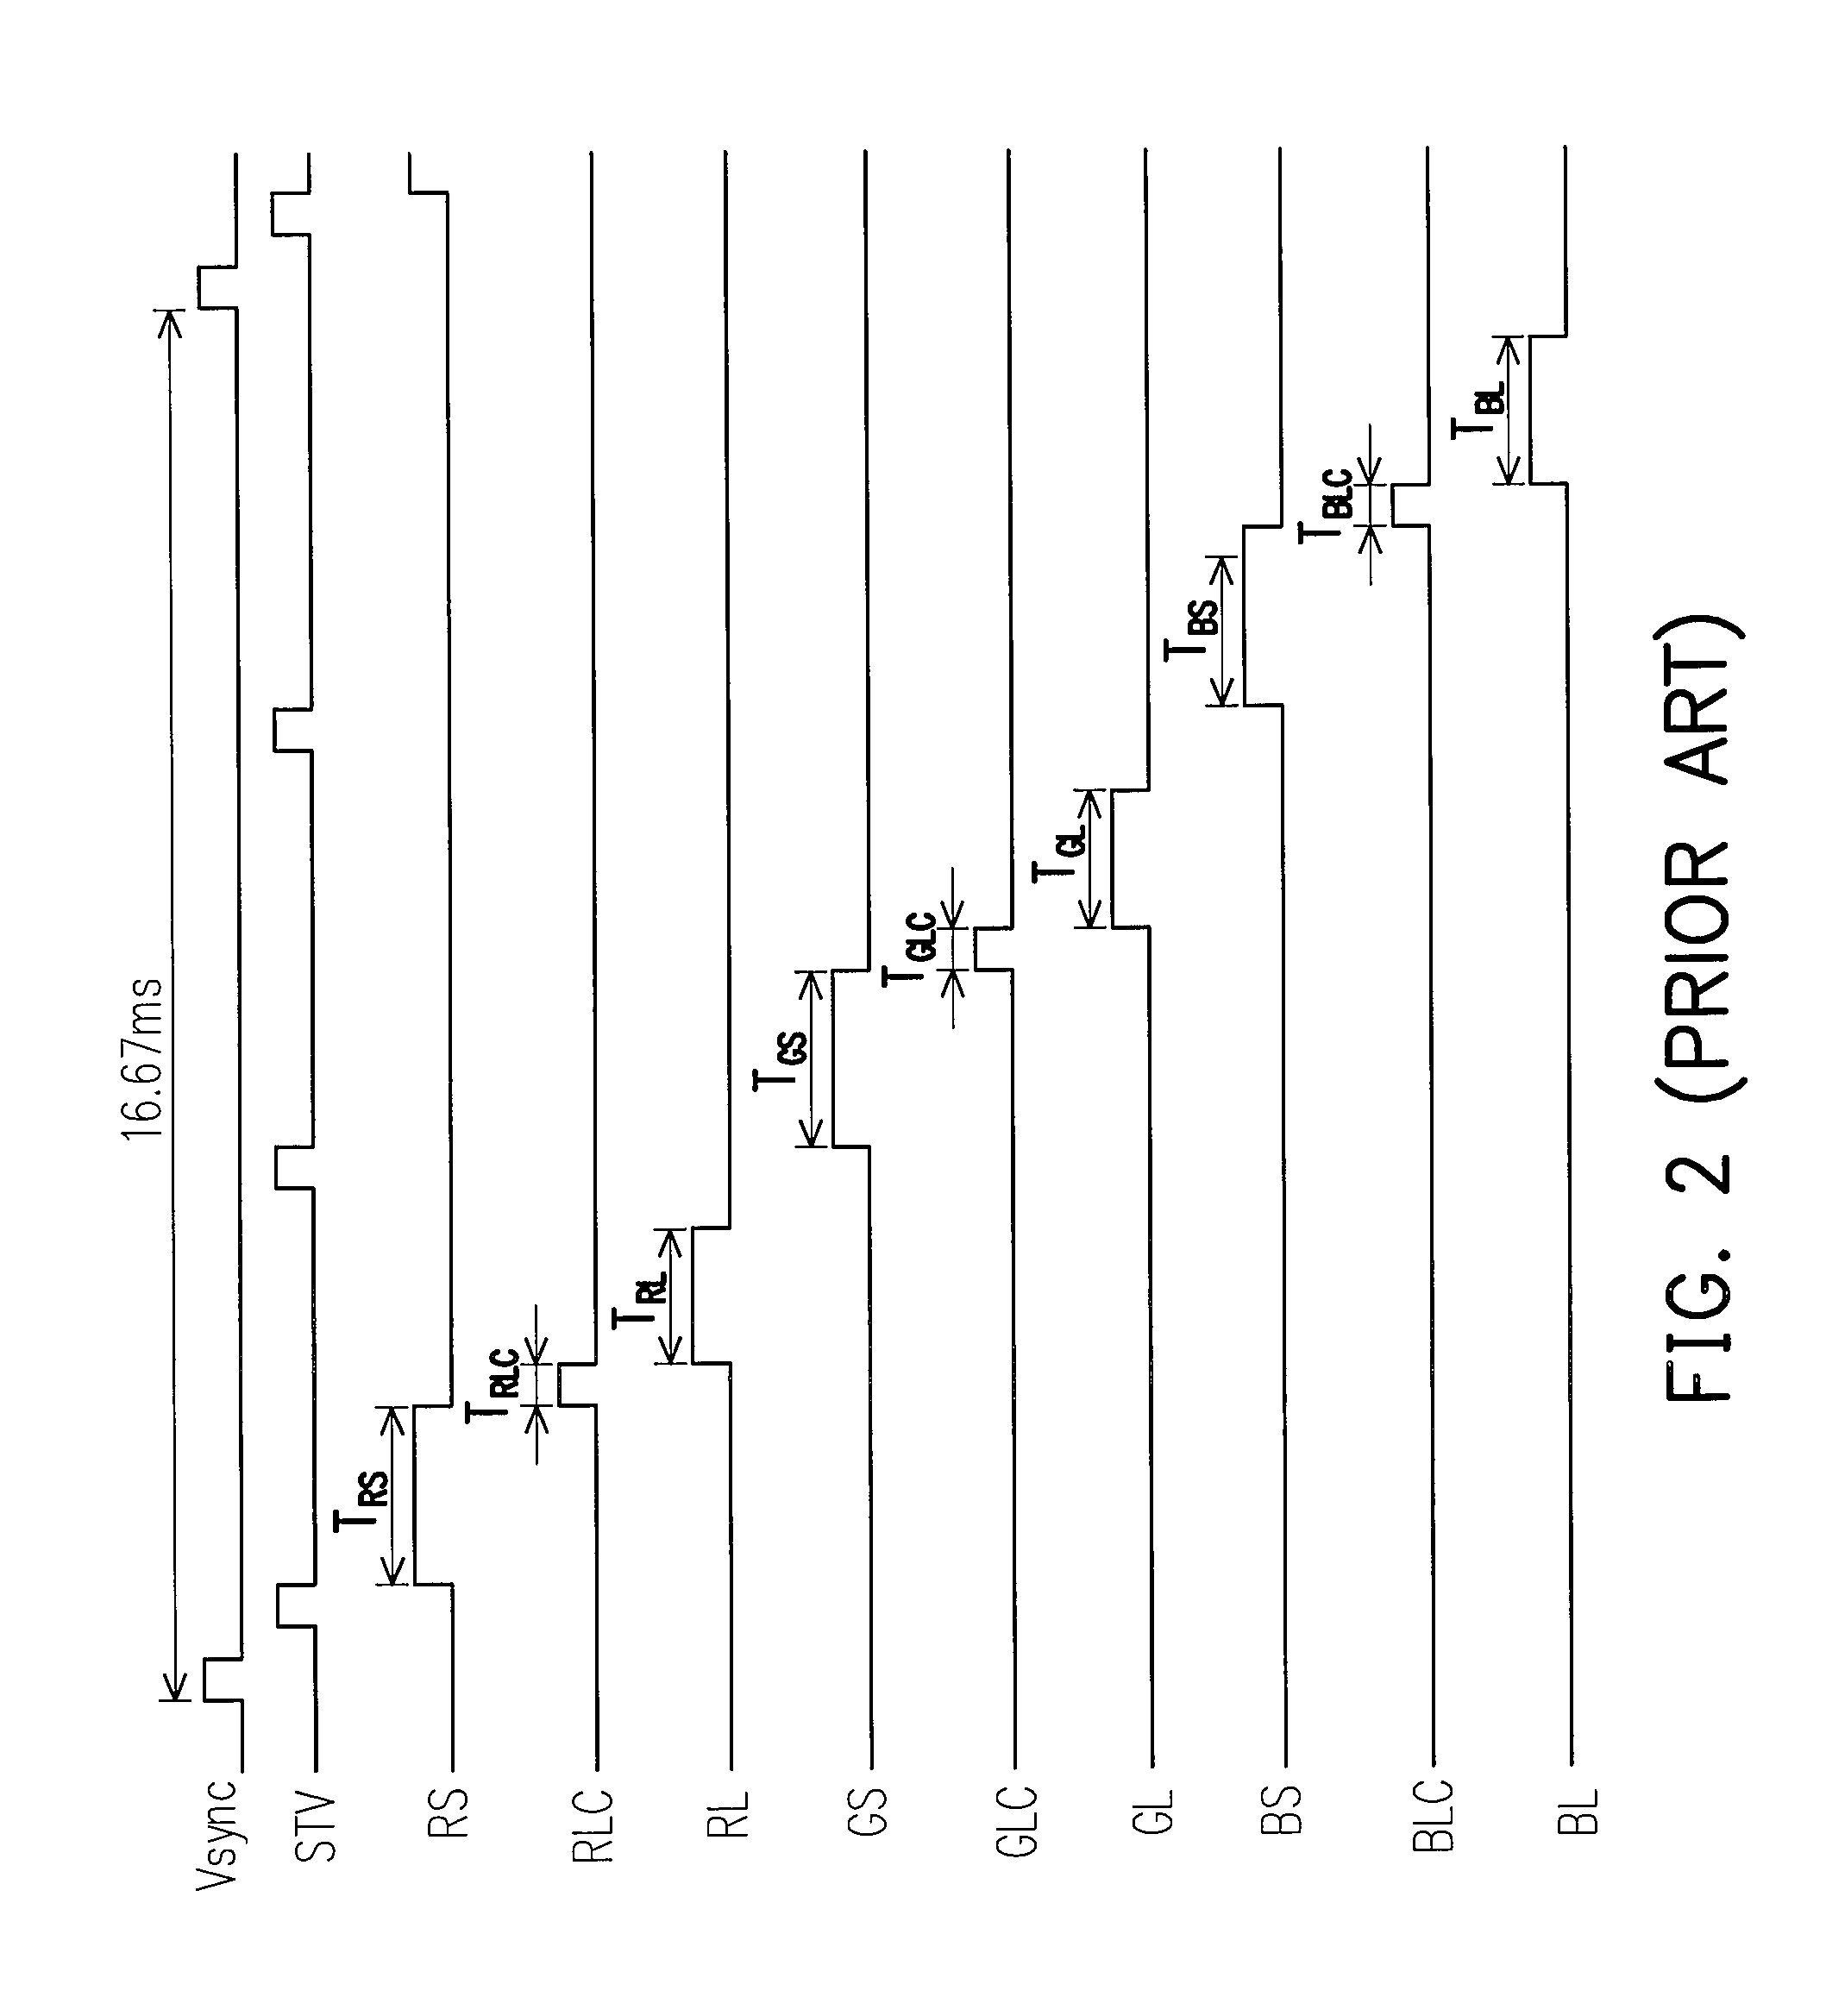
Owner:CHUNGHWA PICTURE TUBES LTD
Control system for traffic signal lamp
InactiveCN109147351AOptimal distribution of lighting timesReduce backlogControlling traffic signalsTraffic capacityImaging processing
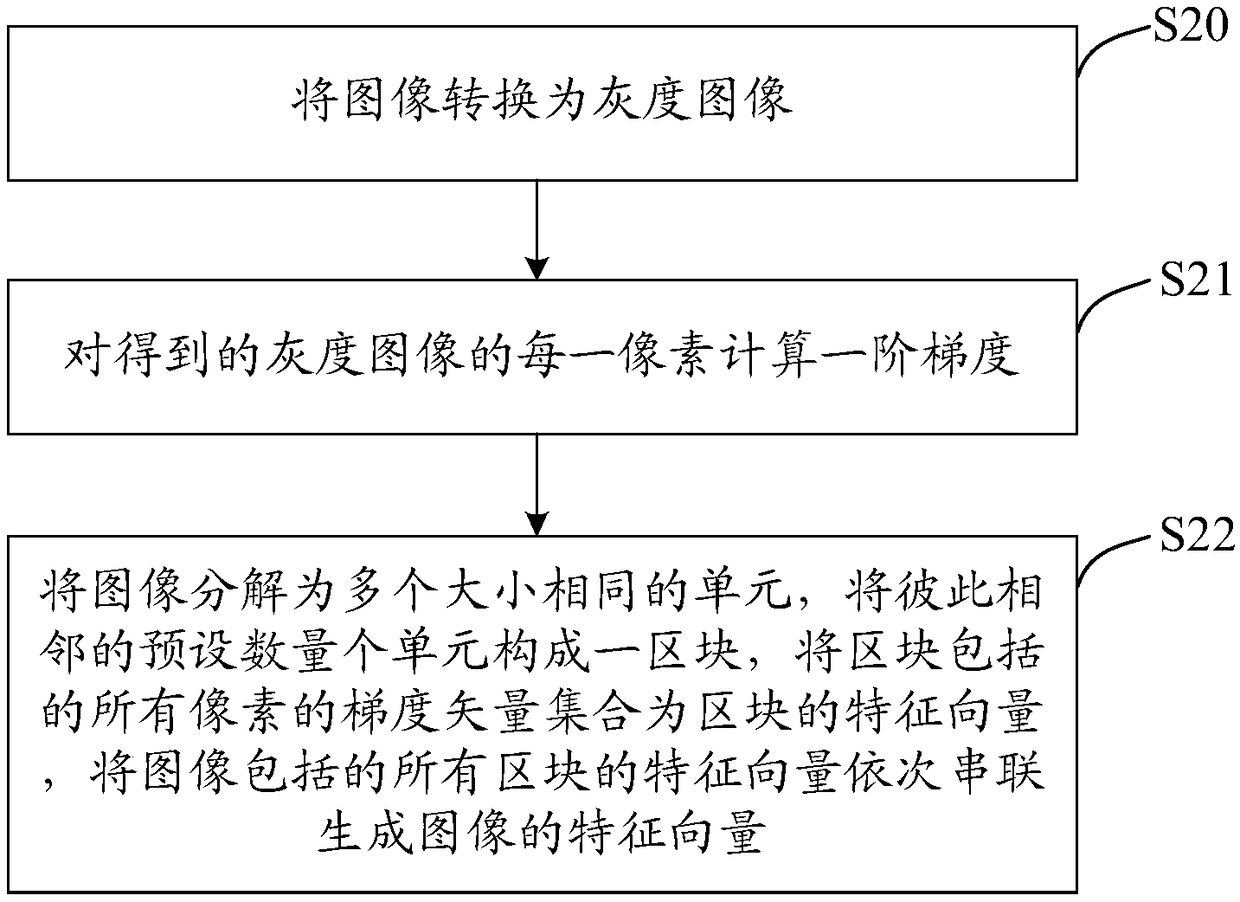
The invention discloses a control system for a traffic signal lamp. The system includes an image acquisition module, an image processing module, a time distribution module, and a signal lamp control module. The image acquisition module separately obtains road surface images of road sections intersecting at a same intersection; the image processing module detects vehicle characteristics from the images, and separately counts traffic flow data of vehicles travelling in different directions on each of the road sections; the time distribution module comprehensively analyzes the traffic flow data of the vehicles traveling in different directions each of the road sections, and calculates the light-up time of a pass signal lamp and a forbidding signal lamp corresponding to each of the road sections, so that the vehicles on each of the road sections pass through the intersection in the shortest time; and the signal lamp control module separately controls light-on and light-off of the traffic signal lamps corresponding to each of the road sections, according to a calculated calculation result of the light-up time of the traffic signal lamps corresponding to each of the road sections. The control system for the traffic signal lamp achieves optimized distribution of the lighting time of the traffic signal lamps disposed on traffic intersections corresponding to each of the road sections,thus helping to reduce a situation of vehicle backlog on traffic road sections.
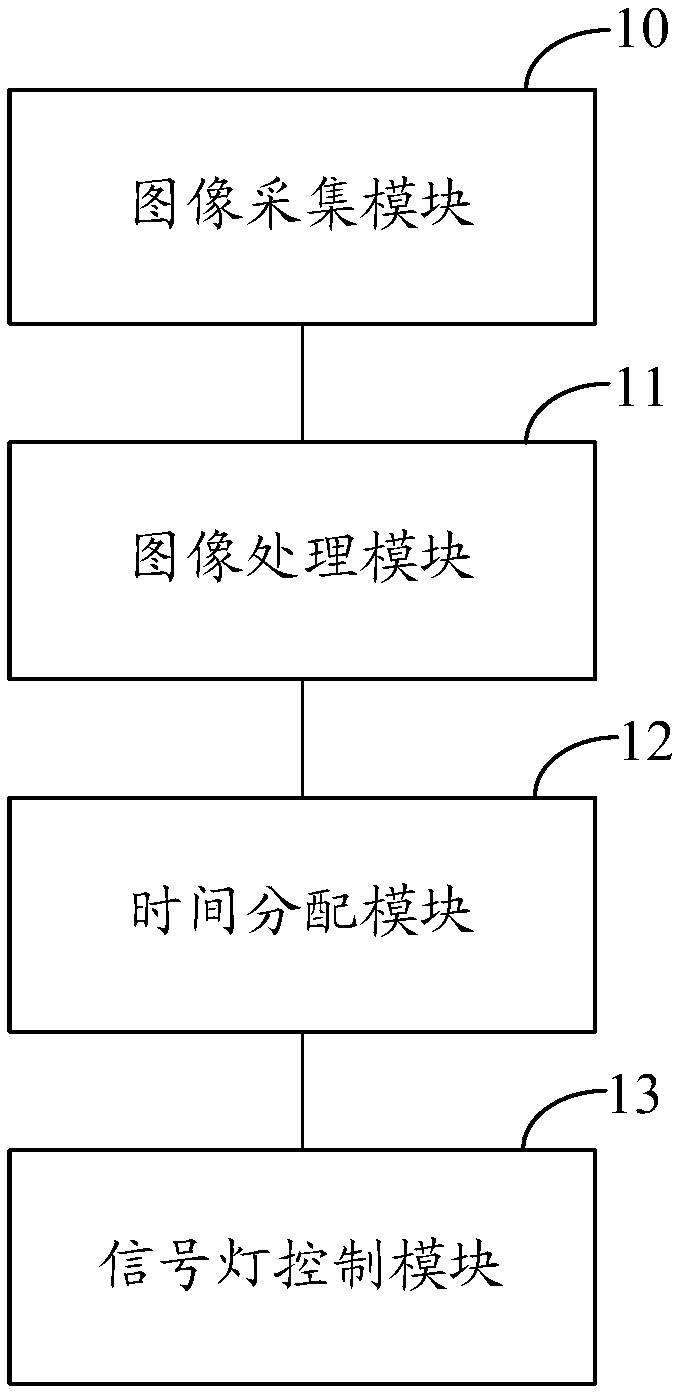
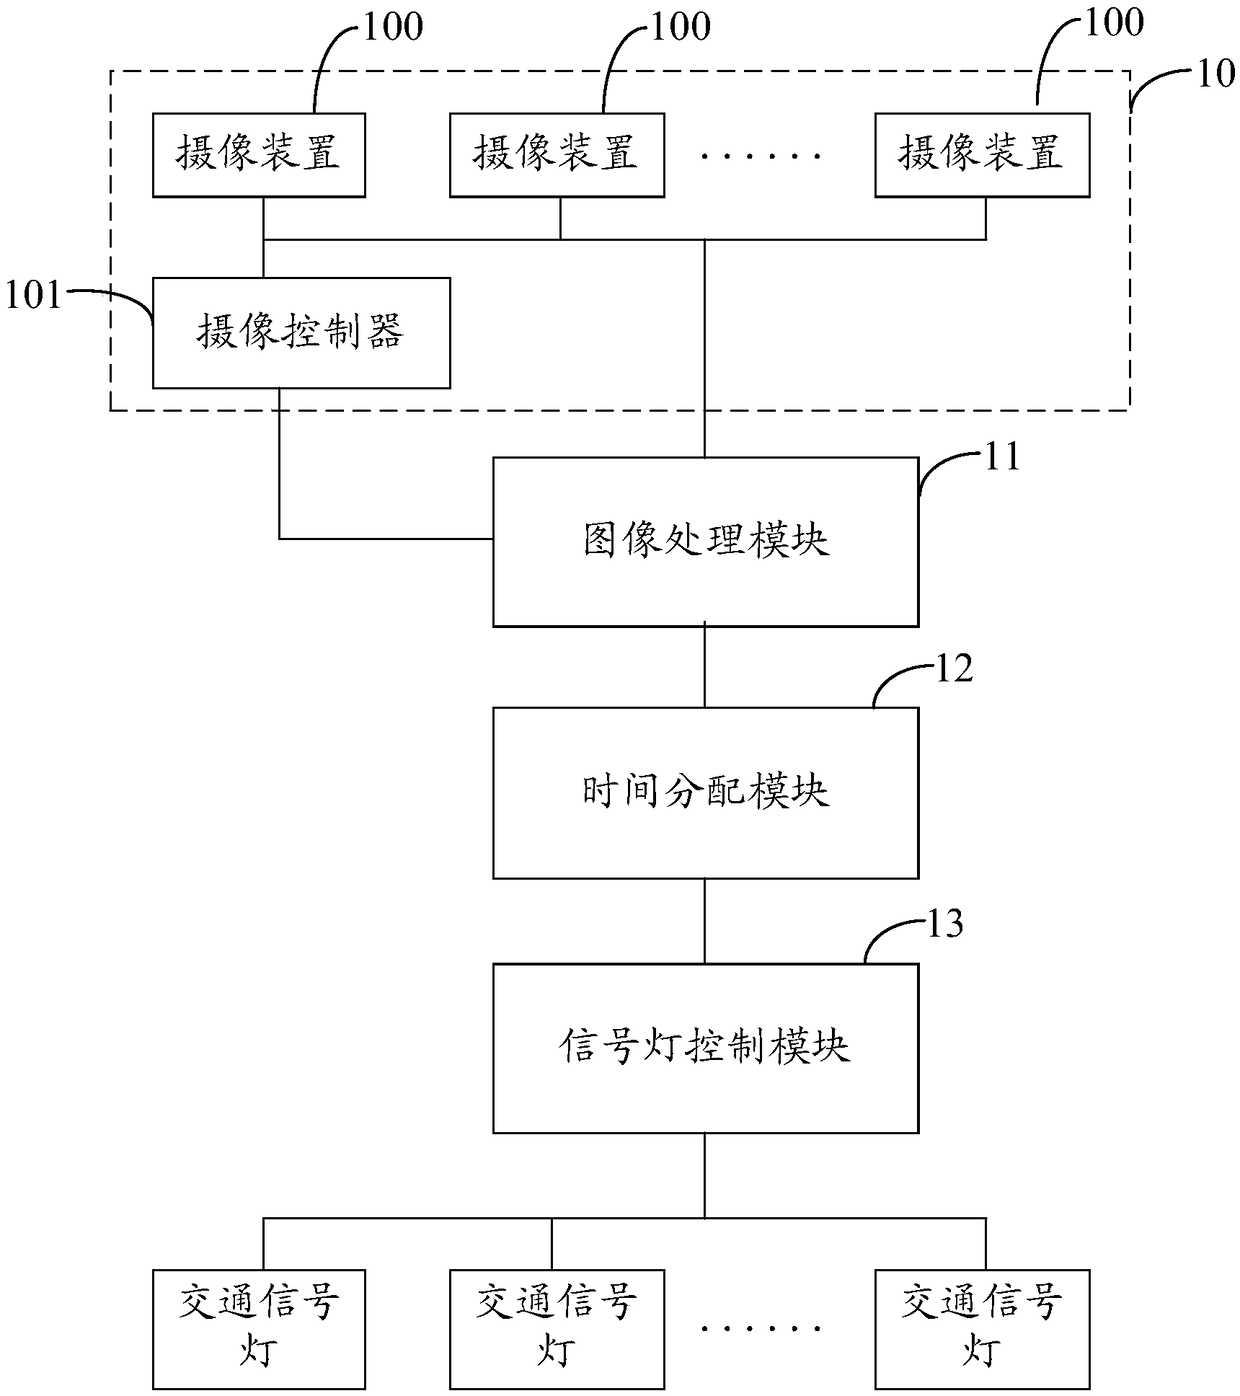
Owner:GUANGDONG UNIV OF TECH
Traffic light control method and control system
InactiveCN110111588AGive full play to traffic capacityImprove traffic efficiencyControlling traffic signalsControl systemLighting-up time
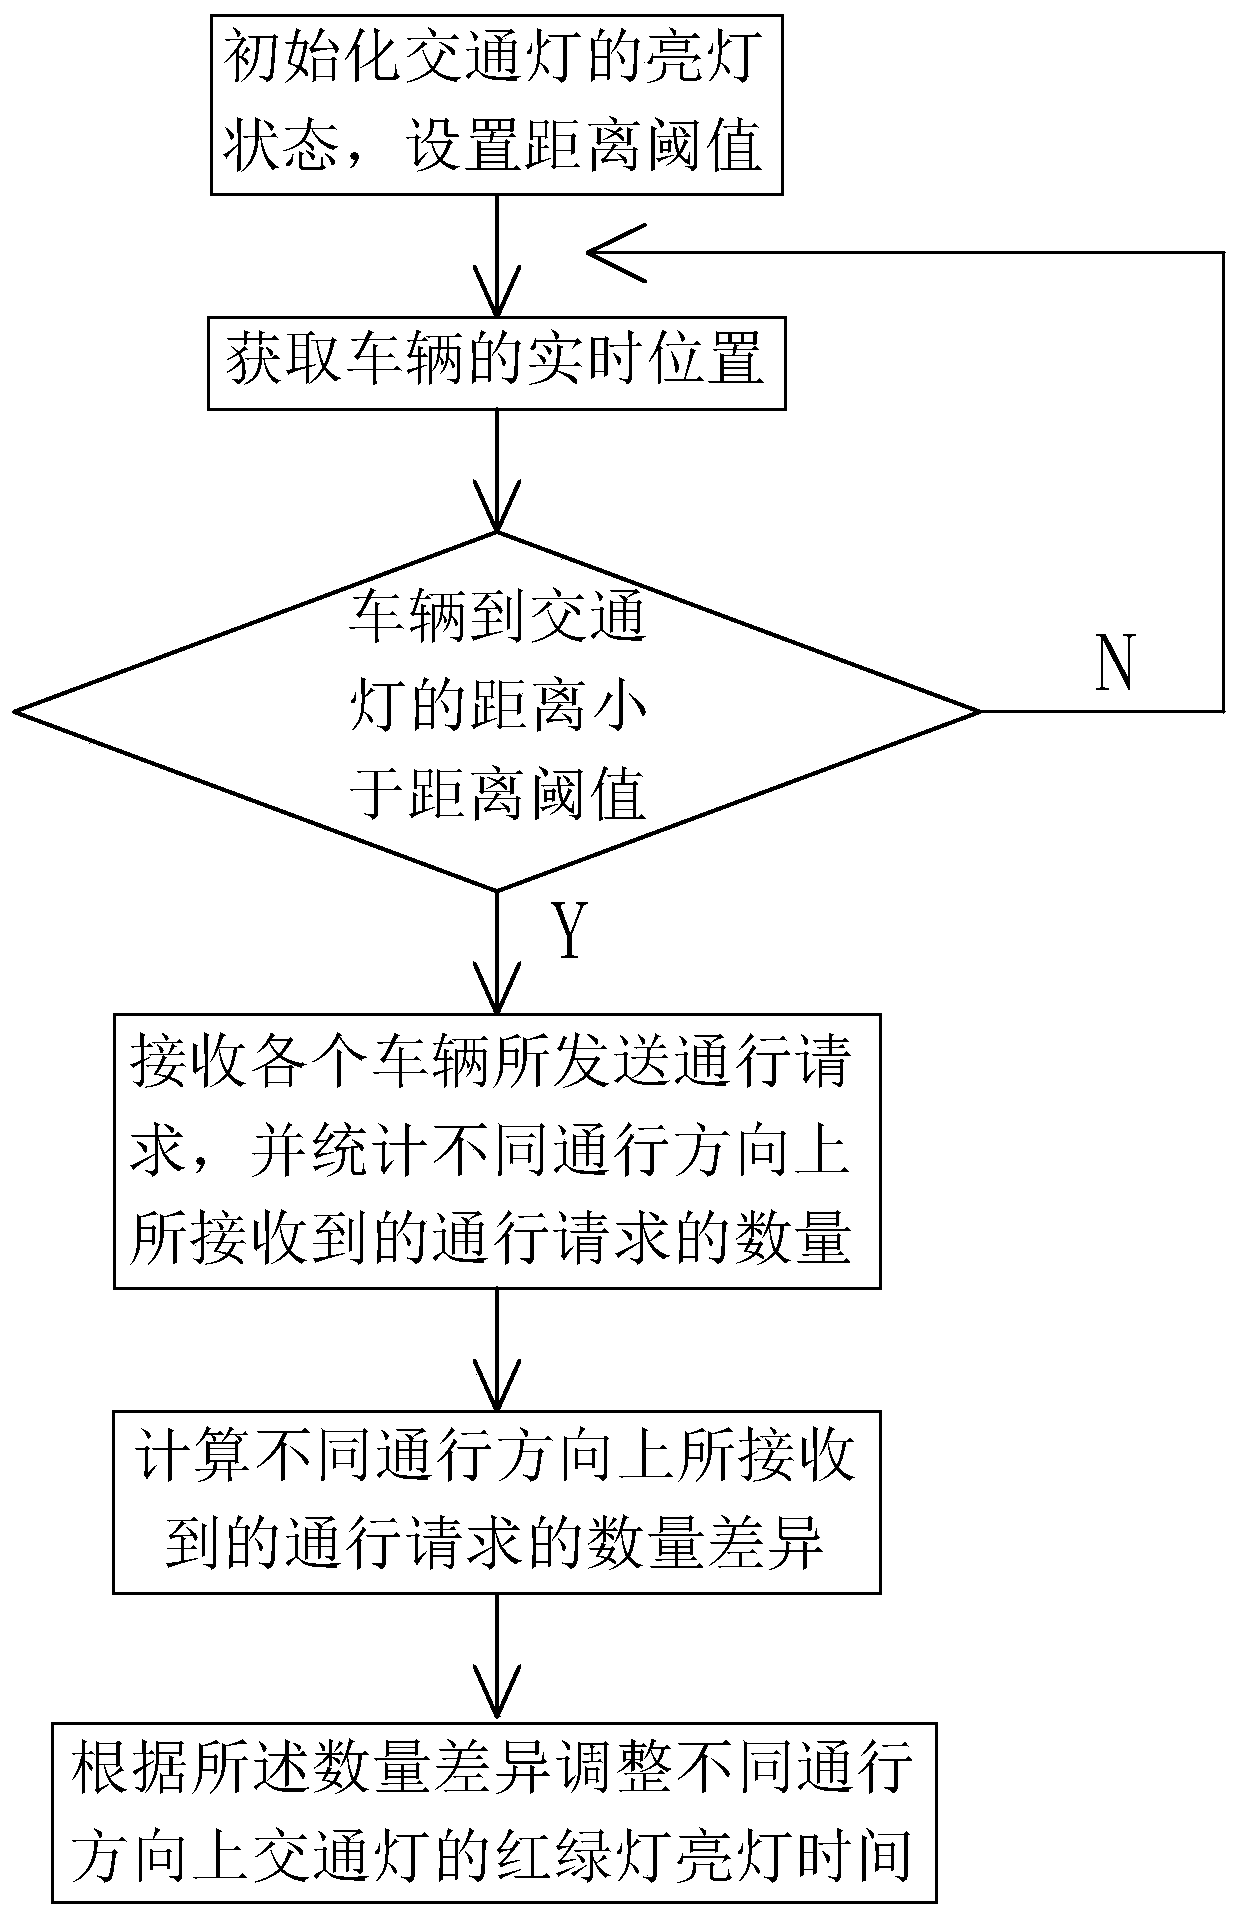
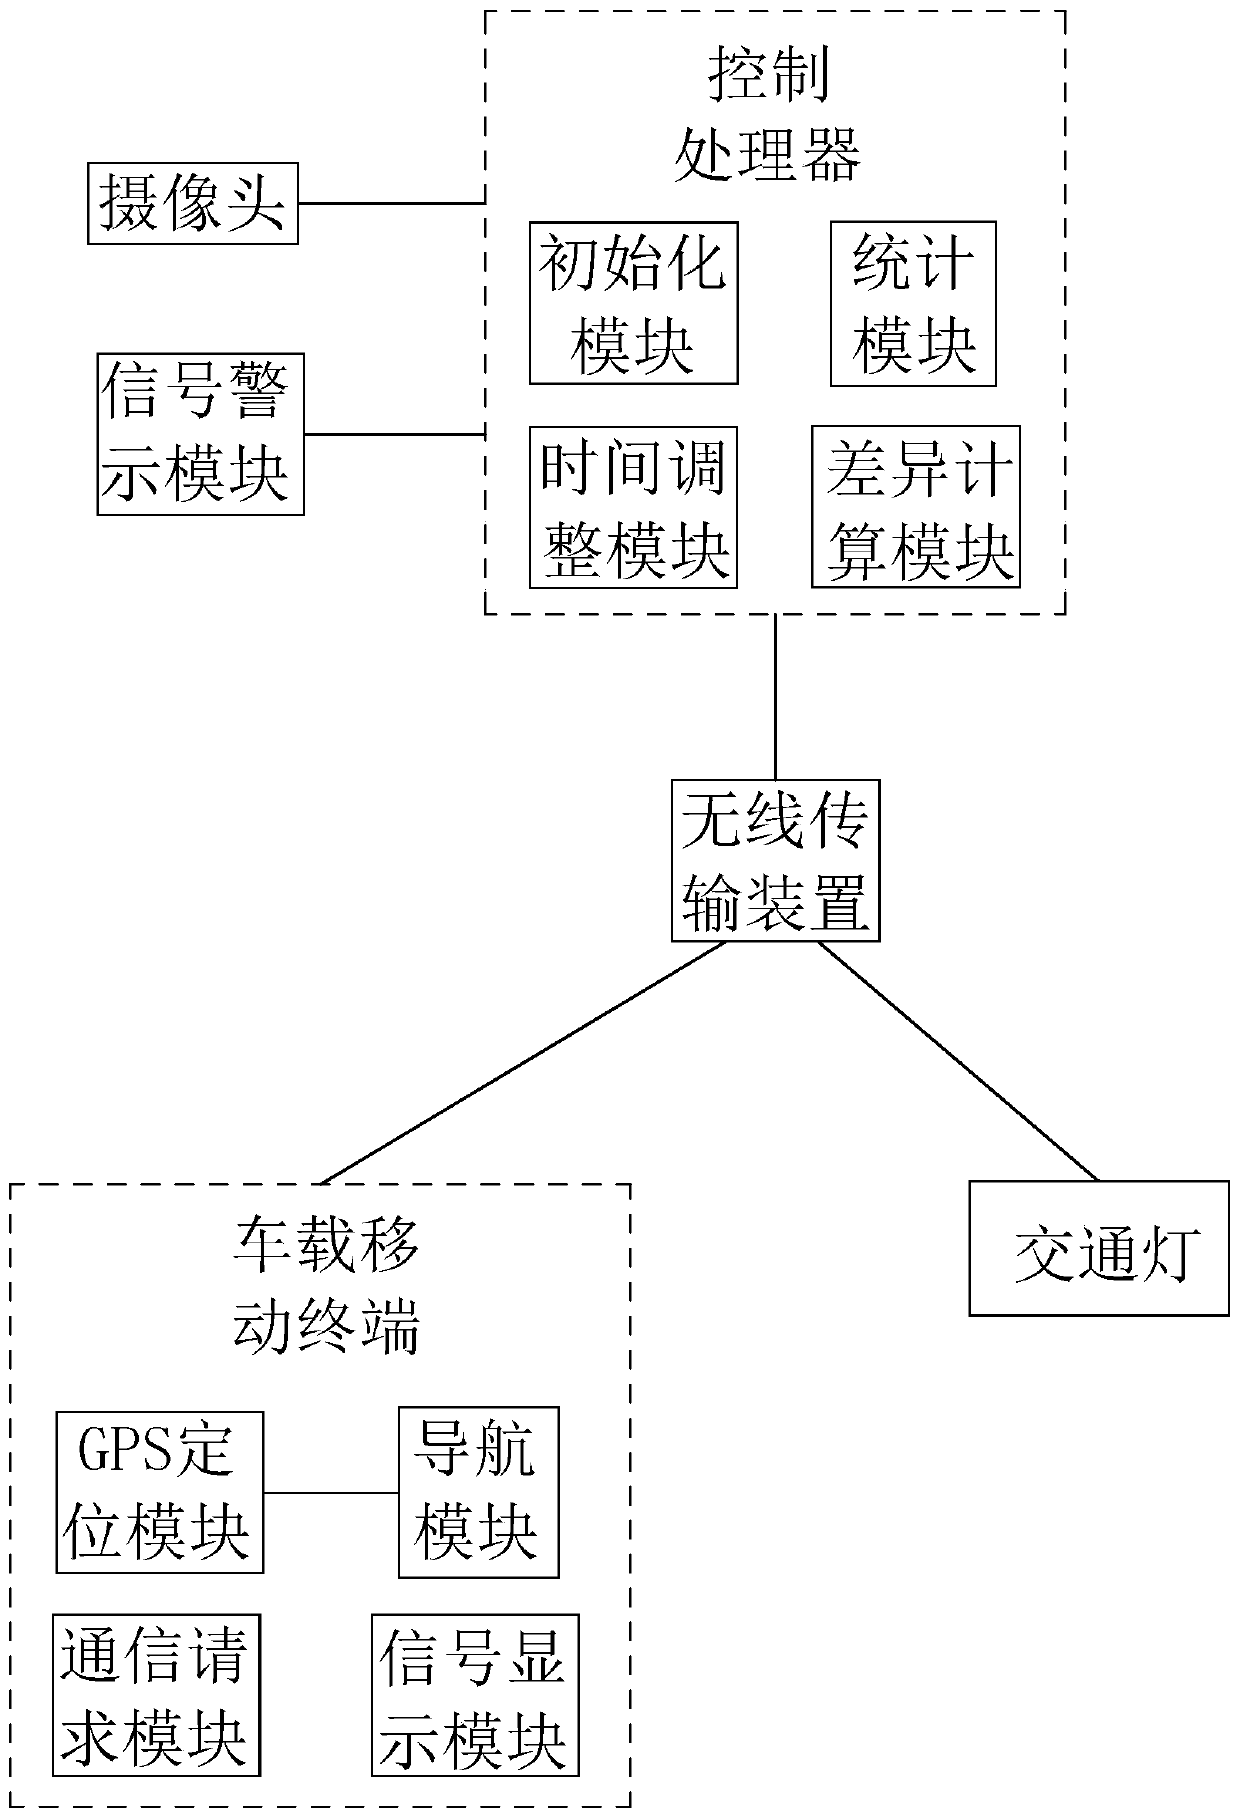
The invention discloses a traffic light control method and control system. The control method includes the following steps that: the lighting-up state of a traffic light is initialized, a distance threshold value is set; the real-time positions of vehicles are acquired, and when it is detected distance between the vehicles and the traffic light are smaller than the distance threshold value, the vehicles send passage requests; the passage requests sent by the vehicles are received, and the quantities of the passage requests received in different passage directions is put into statistics; and the quantity difference of the passage requests received in the different passage directions is calculated, and the lighting-up time of the red lamps and green lamps of the traffic light in the different passage directions is adjusted according to the quantity difference. According to the traffic light control method, the passage requests sent by the vehicles in different passage directions are obtained, and the quantity difference of the passage requests received in the different passage directions is calculated; and the lighting-up time of the red lamps and green lamps of the traffic light inthe different passage directions is adjusted according to the quantity difference; and therefore, the passage capacity of roads is given to full play, the waste of the passage resources of the roadsis prevented, and the passage efficiency of the roads is improved.
Owner:FOSHAN POLYTECHNIC
Liquid Crystal Display Device
InactiveUS20090213053A1Reduce viewing angle dependenceReduce dependenceCathode-ray tube indicatorsNon-linear opticsLiquid-crystal displayLighting-up time
A liquid crystal display device includes a plurality of pixels each connected to a signal line via a switching element. Each pixel includes first and second sub-pixels having voltage vs. luminance characteristics different from each other with respect to a signal voltage supplied from the signal line. A threshold signal voltage of the first sub-pixel is lower than that of the second sub-pixel. The pixels form color display pixels which are red, green pixel and blue pixels. Where the area ratio of the first sub-pixel in each of the red, green and blue pixels is SR1, SG1 and SB1, and the ratio of the lighting-up time period of the first sub-pixel of each of the red, green and blue pixels in one vertical scanning period is TR1, TG1 and TB1, the relationship of (SR1×TR1)>(SG1×TG1)>(SB1×TB1) holds.
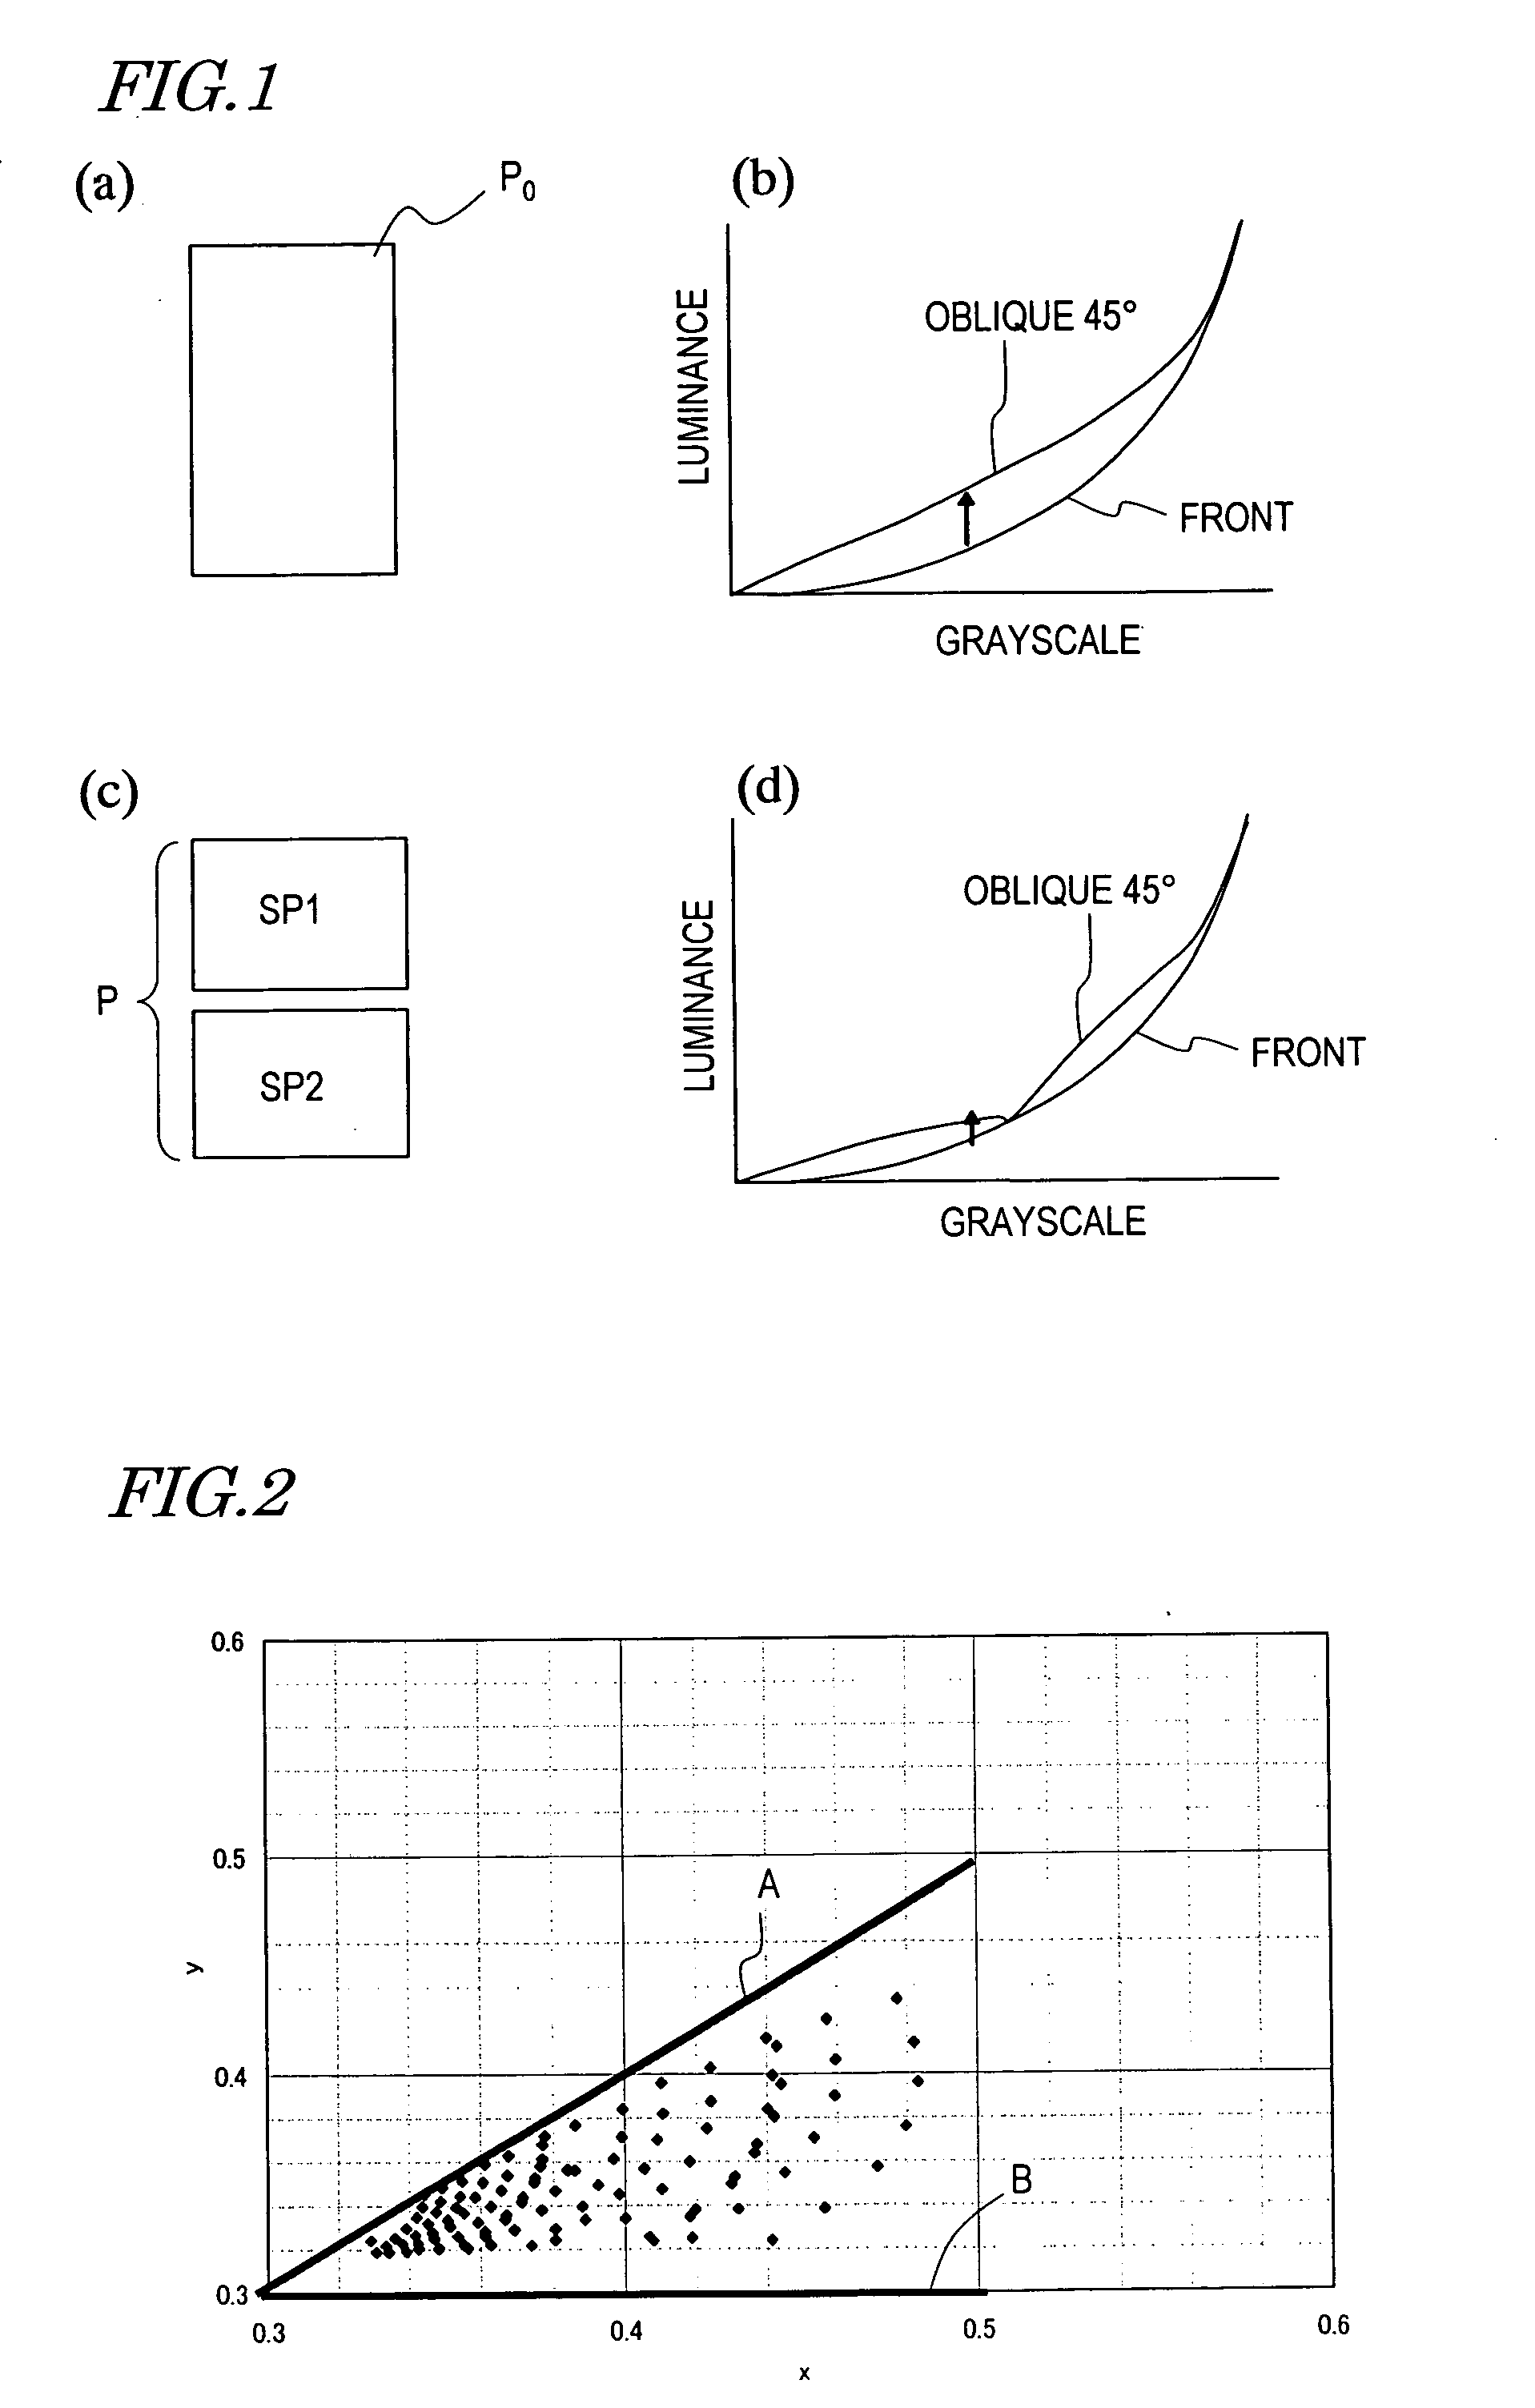
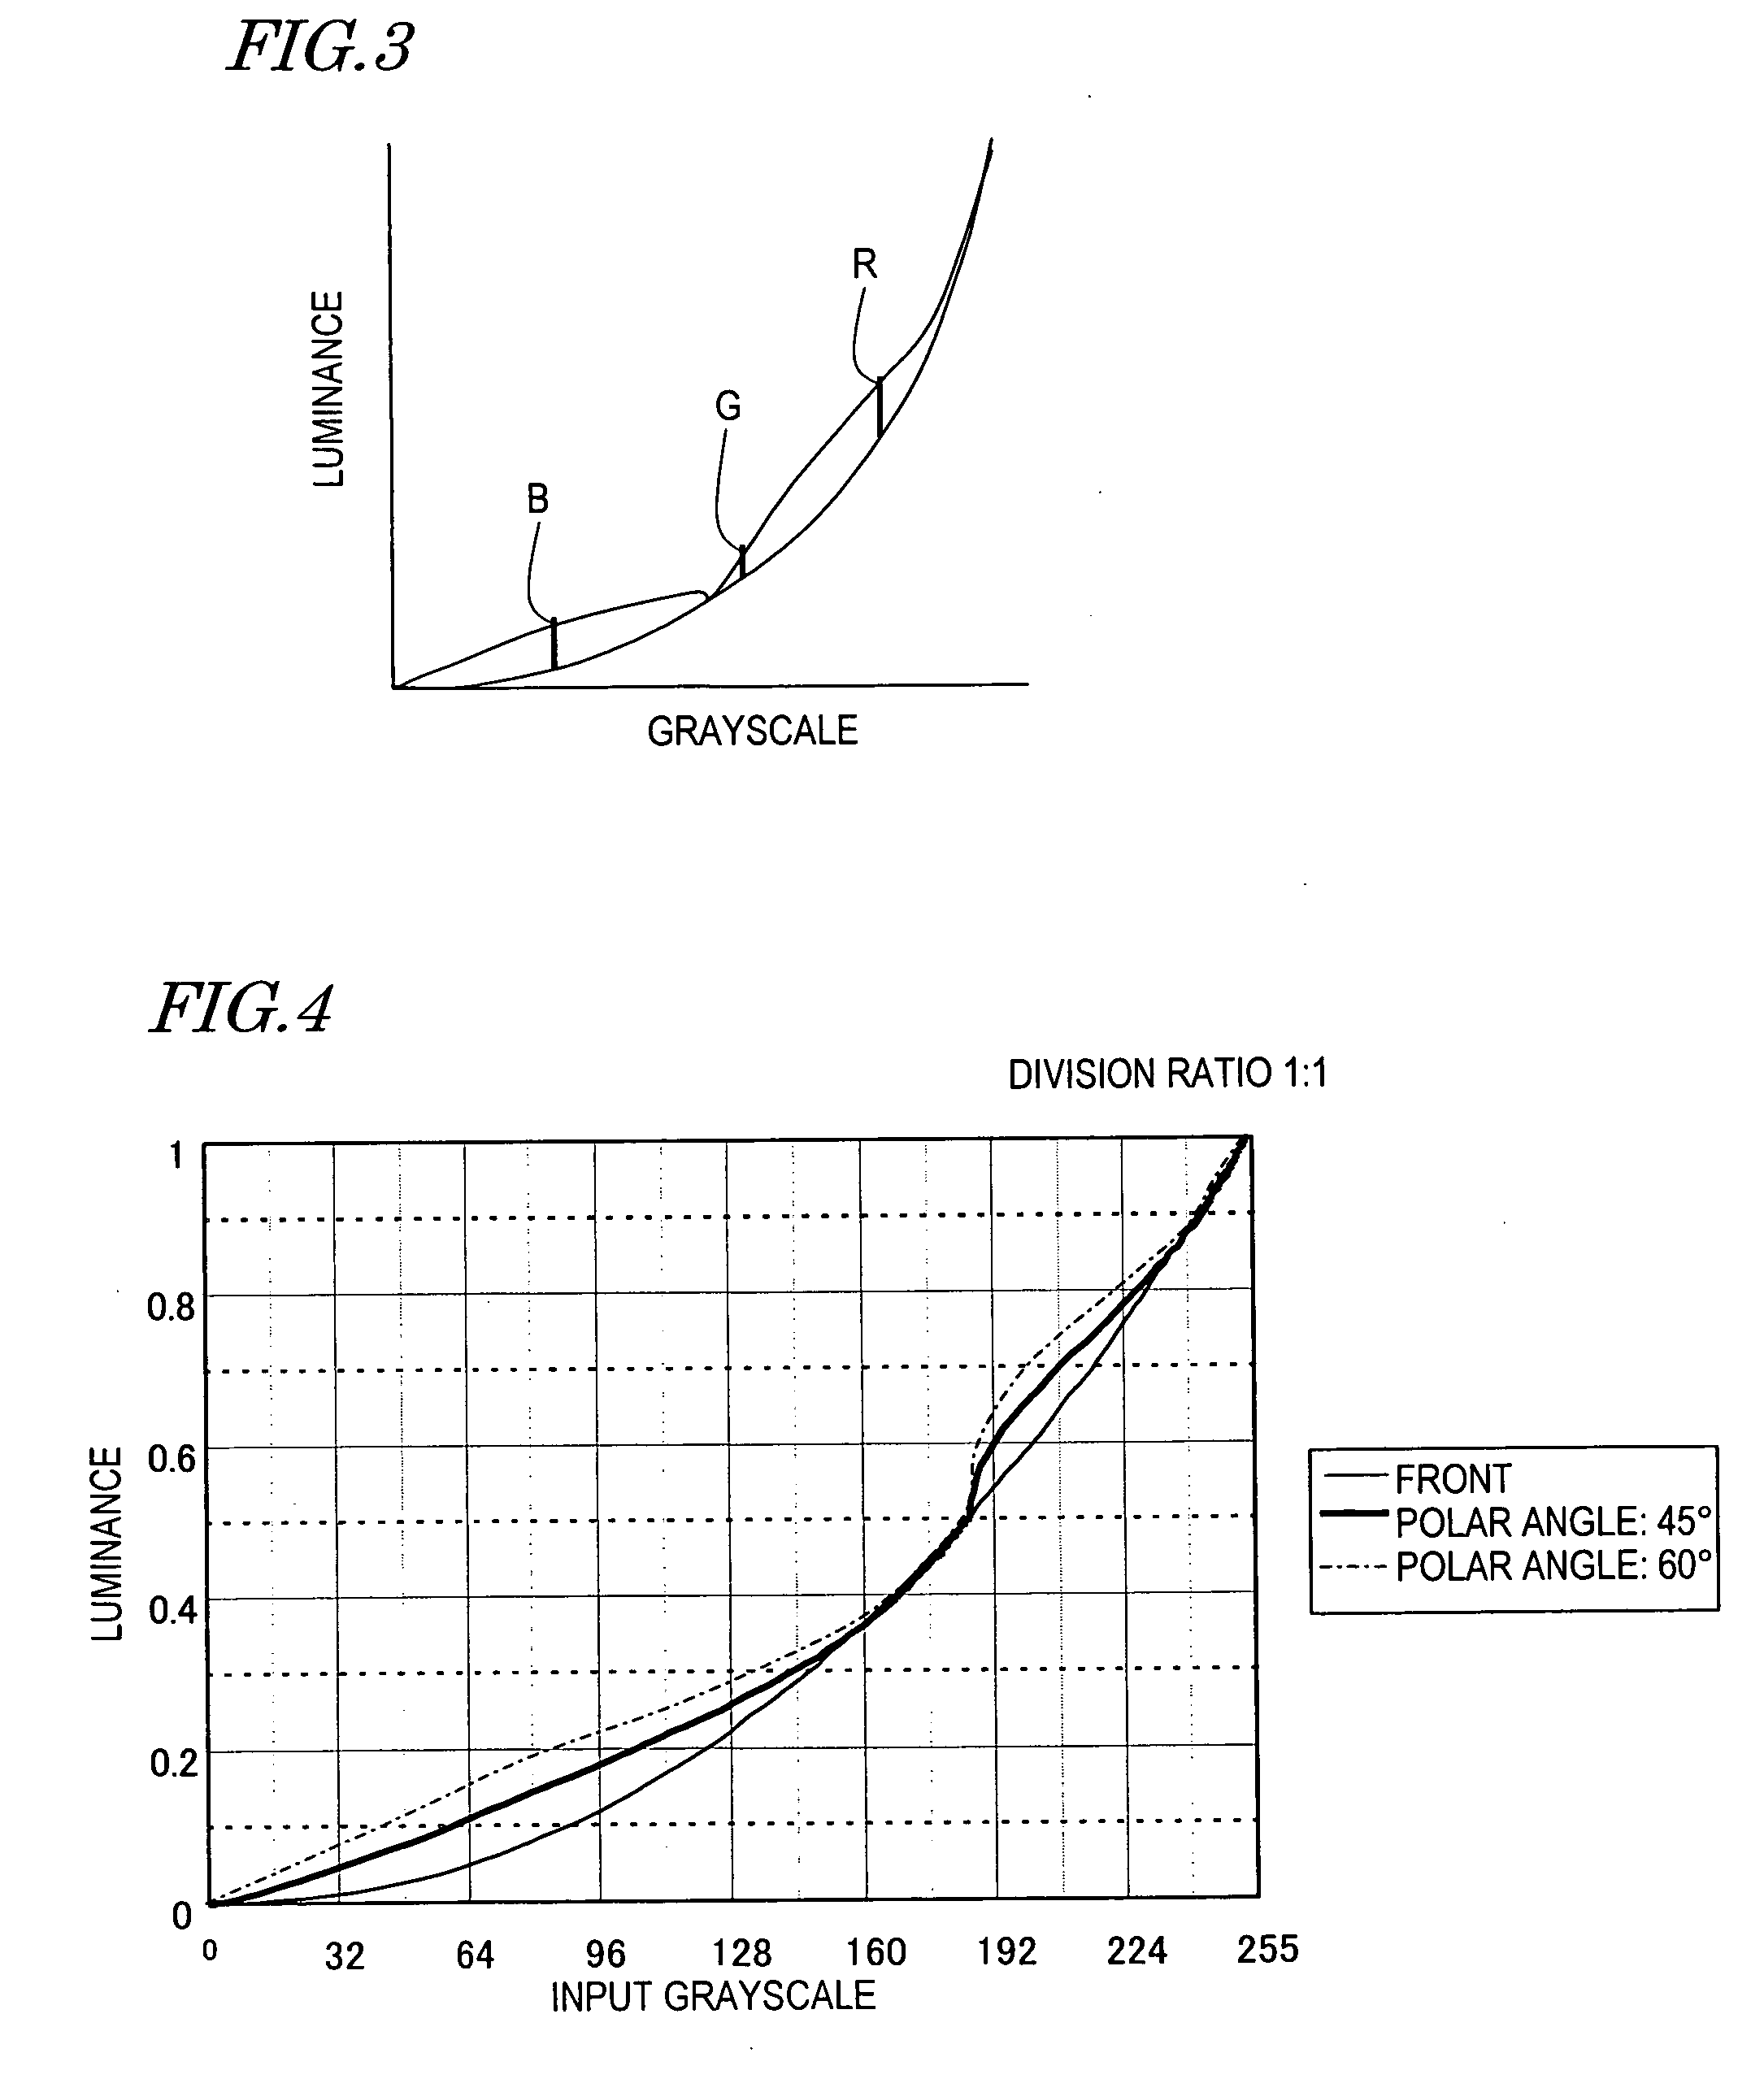
Owner:SHARP KK
Traffic light capable of intelligently adjusting switching time and intelligent adjusting method thereof
InactiveCN109087518AConvenient travelEase traffic pressureControlling traffic signalsControl signalRadar
The invention provides a traffic light capable of intelligently adjusting the switching time. The traffic light comprises a pole body and a signal lamp display module. The pole body is arranged besidean intersection, and the signal lamp module is arranged on the pole body. The traffic light further comprises an intelligent processing system and radar sensors. The radar sensors are arranged on theroad side of a vehicle waiting area of the intersection where the traffic light is located and used for detecting the number of vehicles in the vehicle waiting area. The signal lamp display module and the radar sensors are both connected with the intelligent processing system, and the intelligent processing system reads signals of the radar sensors and outputs control signals of different passageduration to the signal lamp display module. By arranging the radar sensors, the number of the vehicle in the vehicle waiting area is monitored in real time, the lighting-up time of each traffic lightbody is adjusted according to the monitoring result, the traffic pressure can be effectively relieved, the time of people is saved, and traveling of people is facilitated.
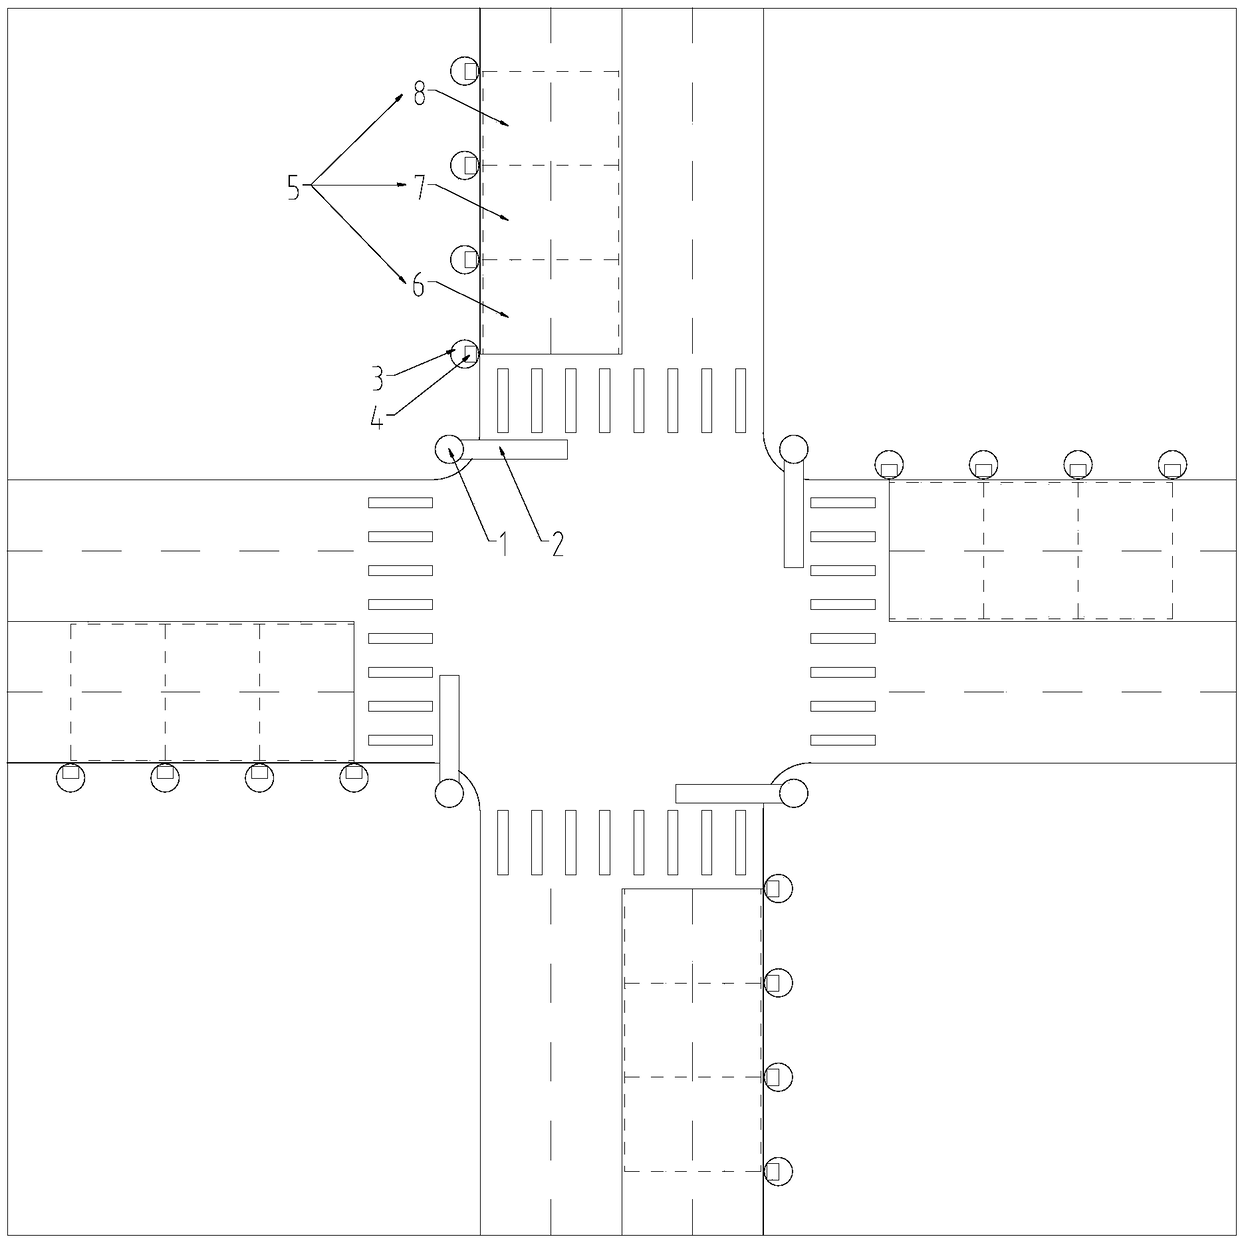
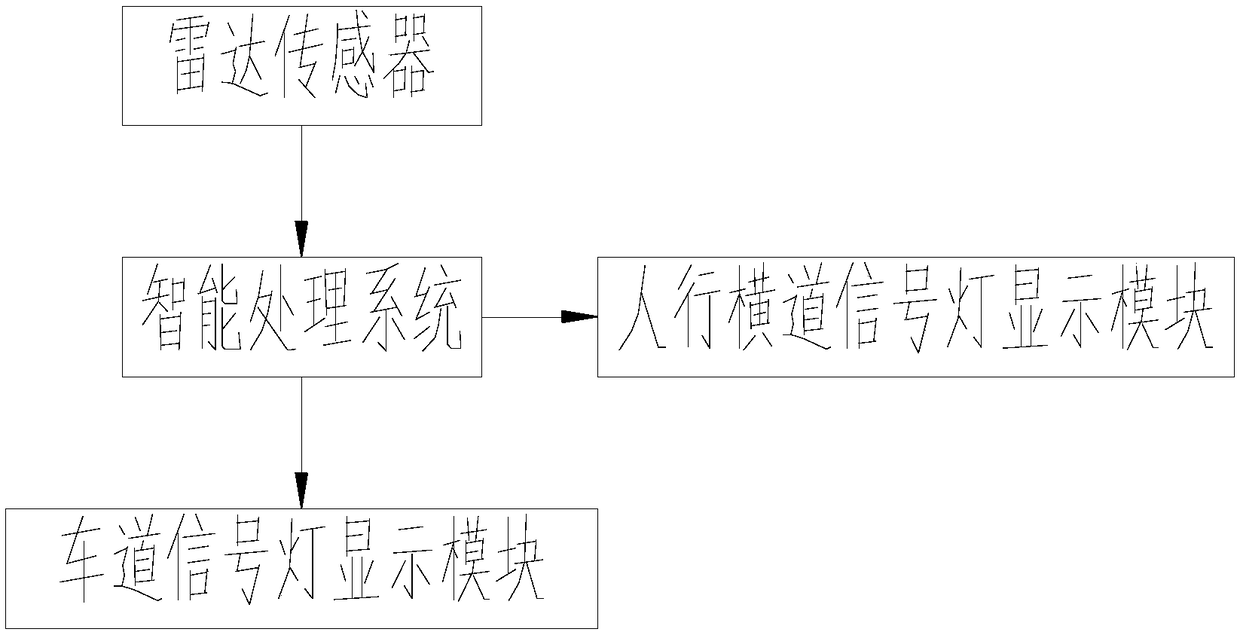
Owner:SHUNDE POLYTECHNIC
Edge exposing apparatus
ActiveUS7088423B2Avoid quality lossReduce delaysSemiconductor/solid-state device manufacturingPhotomechanical exposure apparatusLuminous intensityLighting-up time
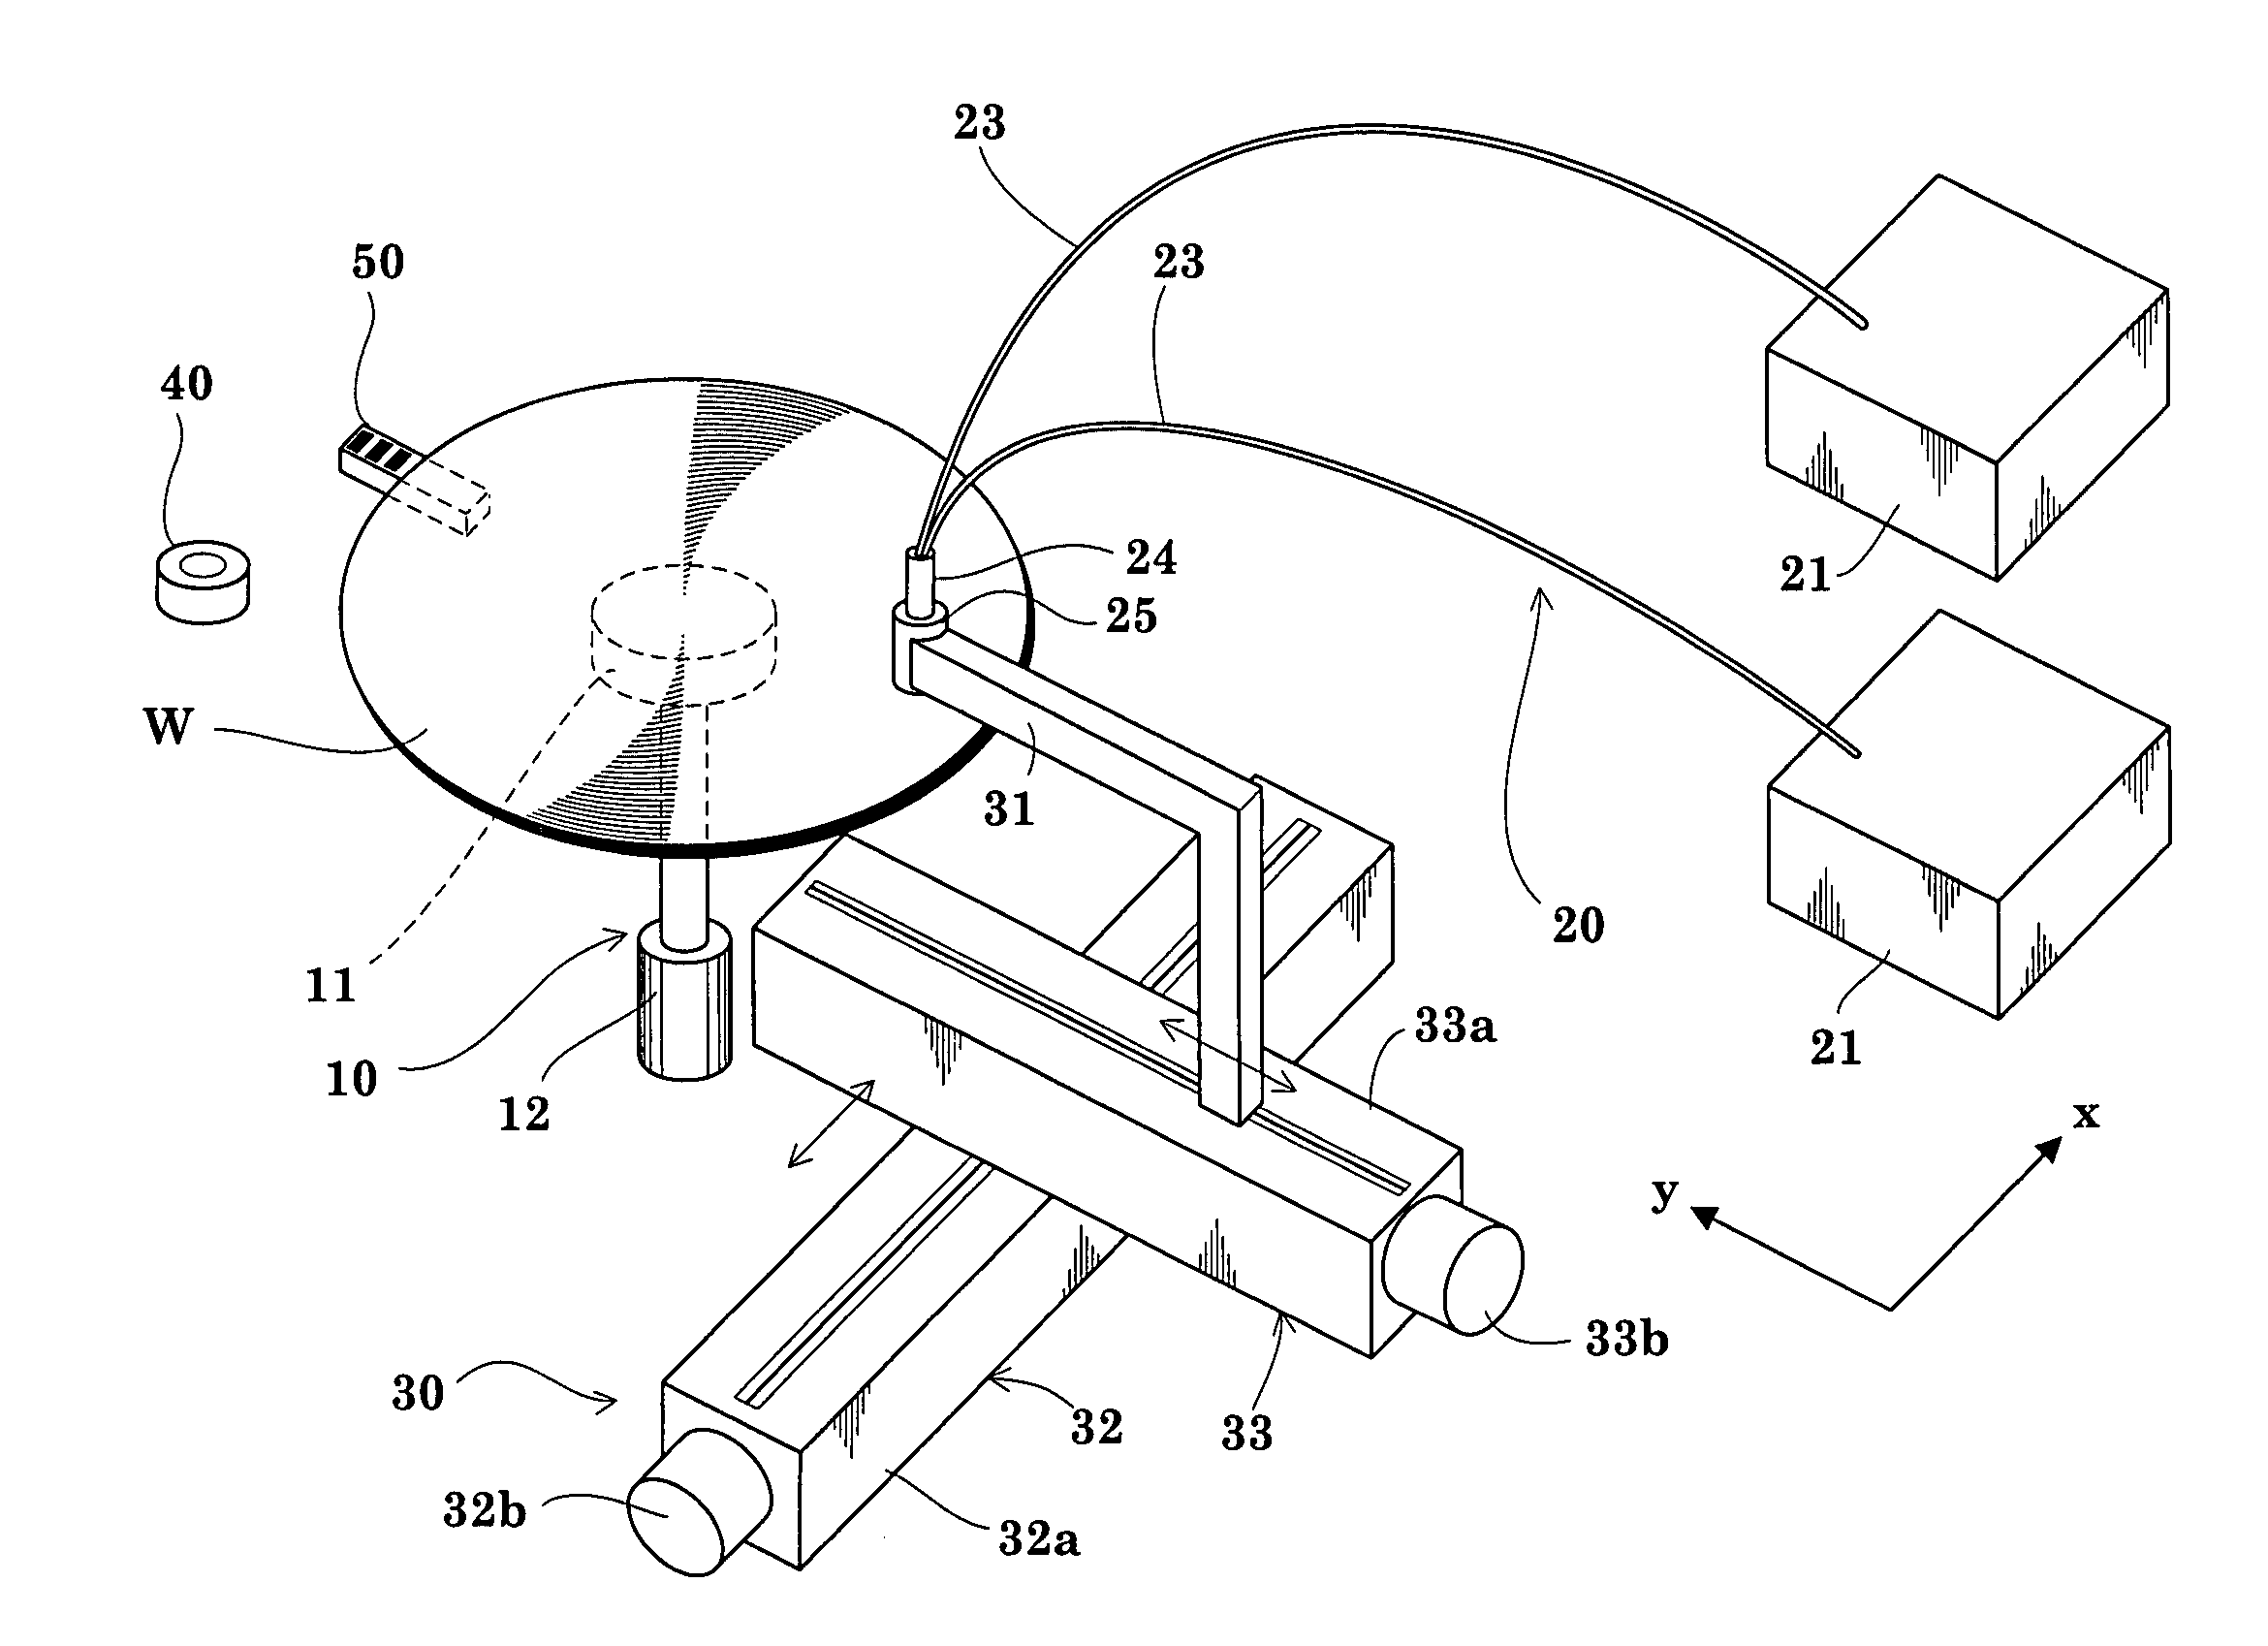
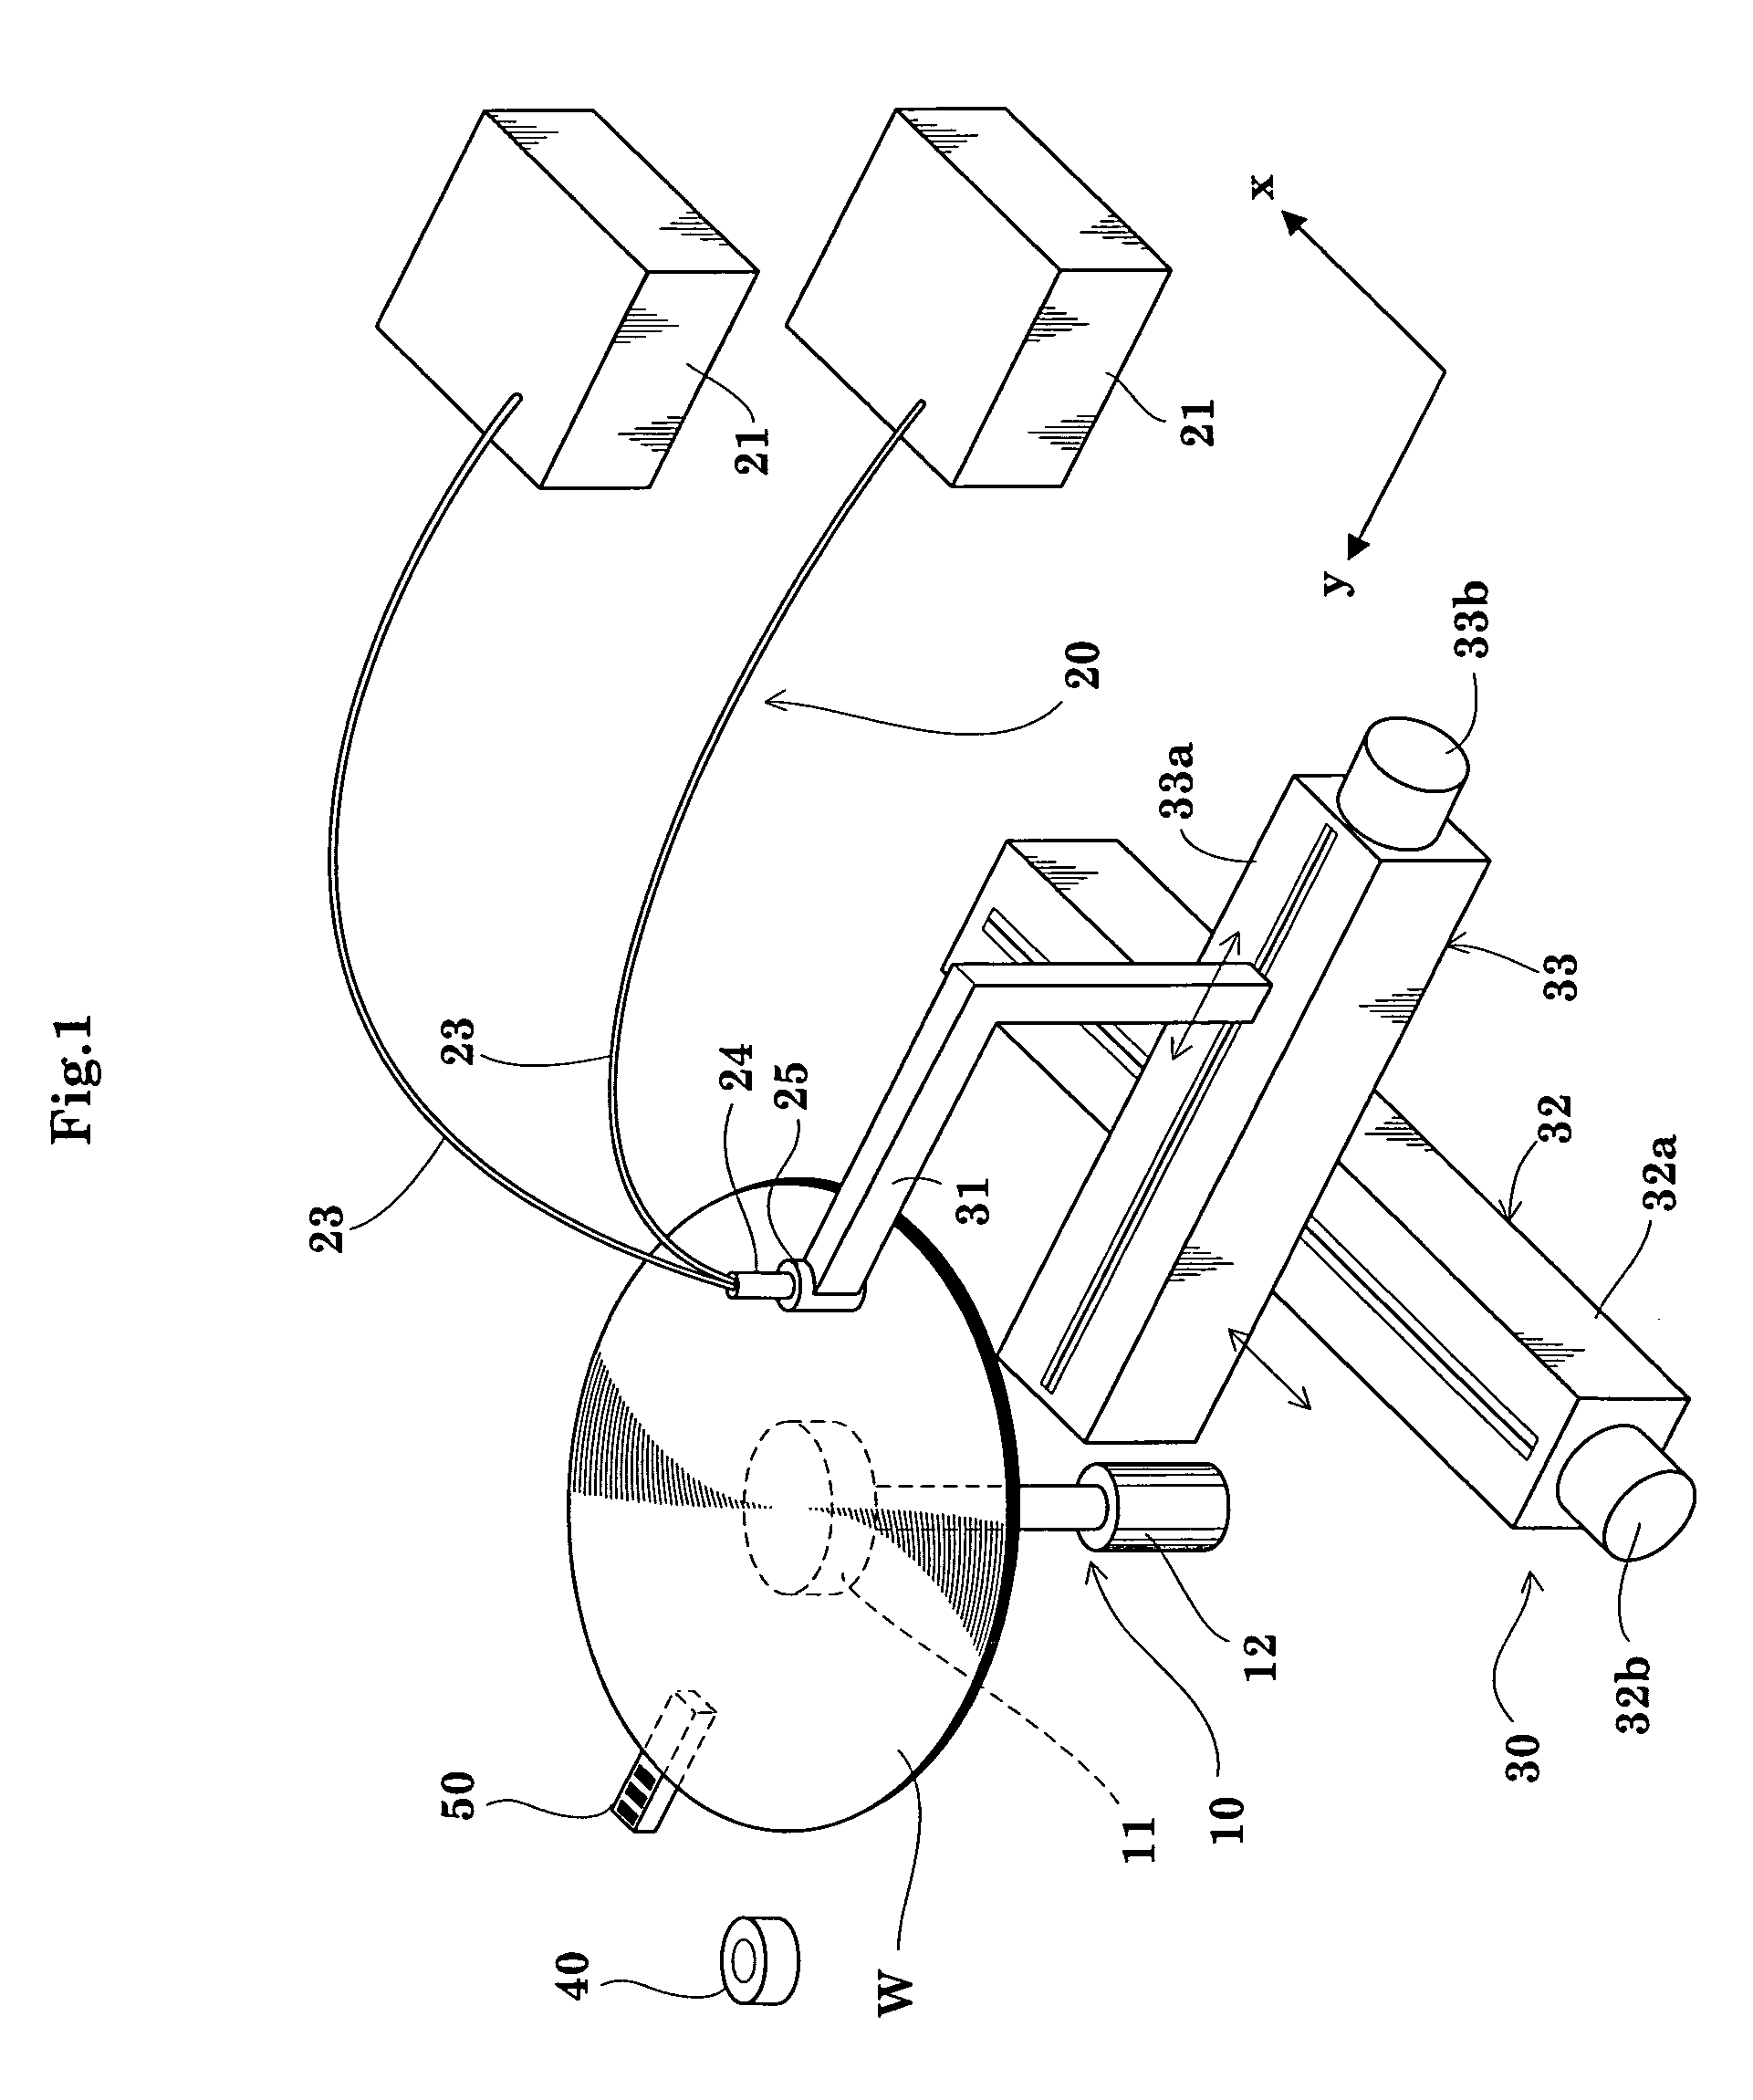
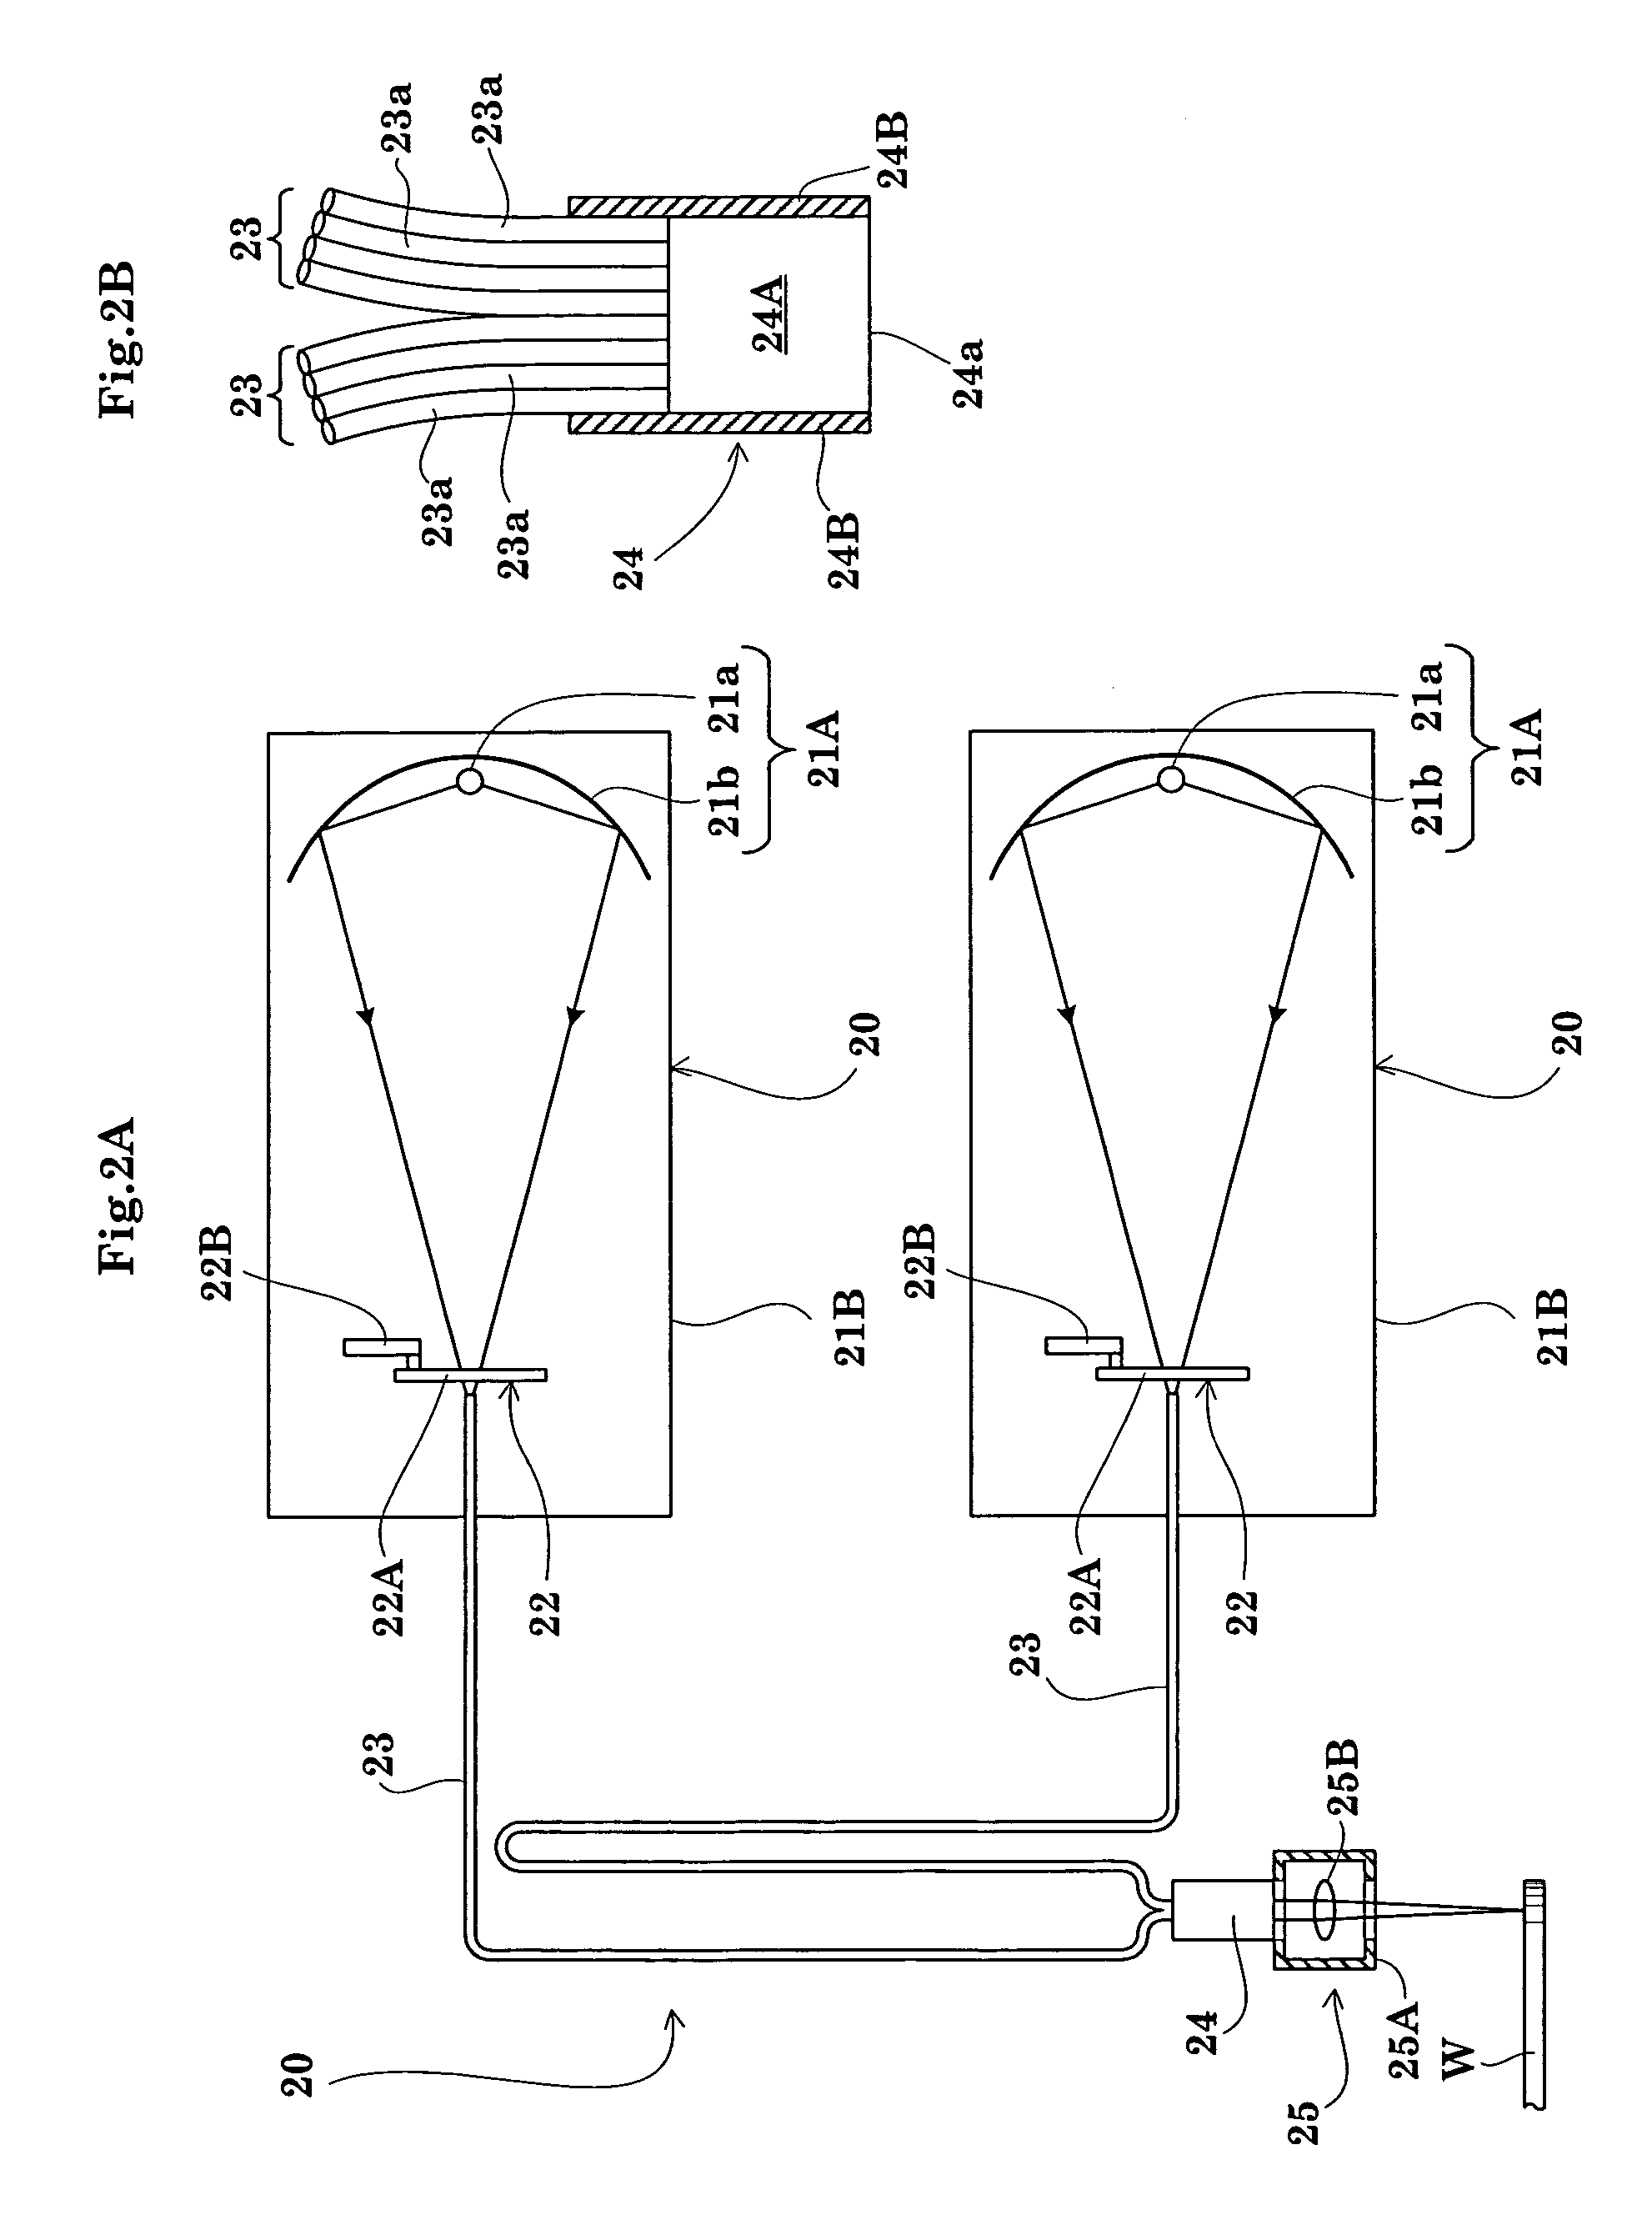
Owner:SCREEN SEMICON SOLUTIONS CO LTD
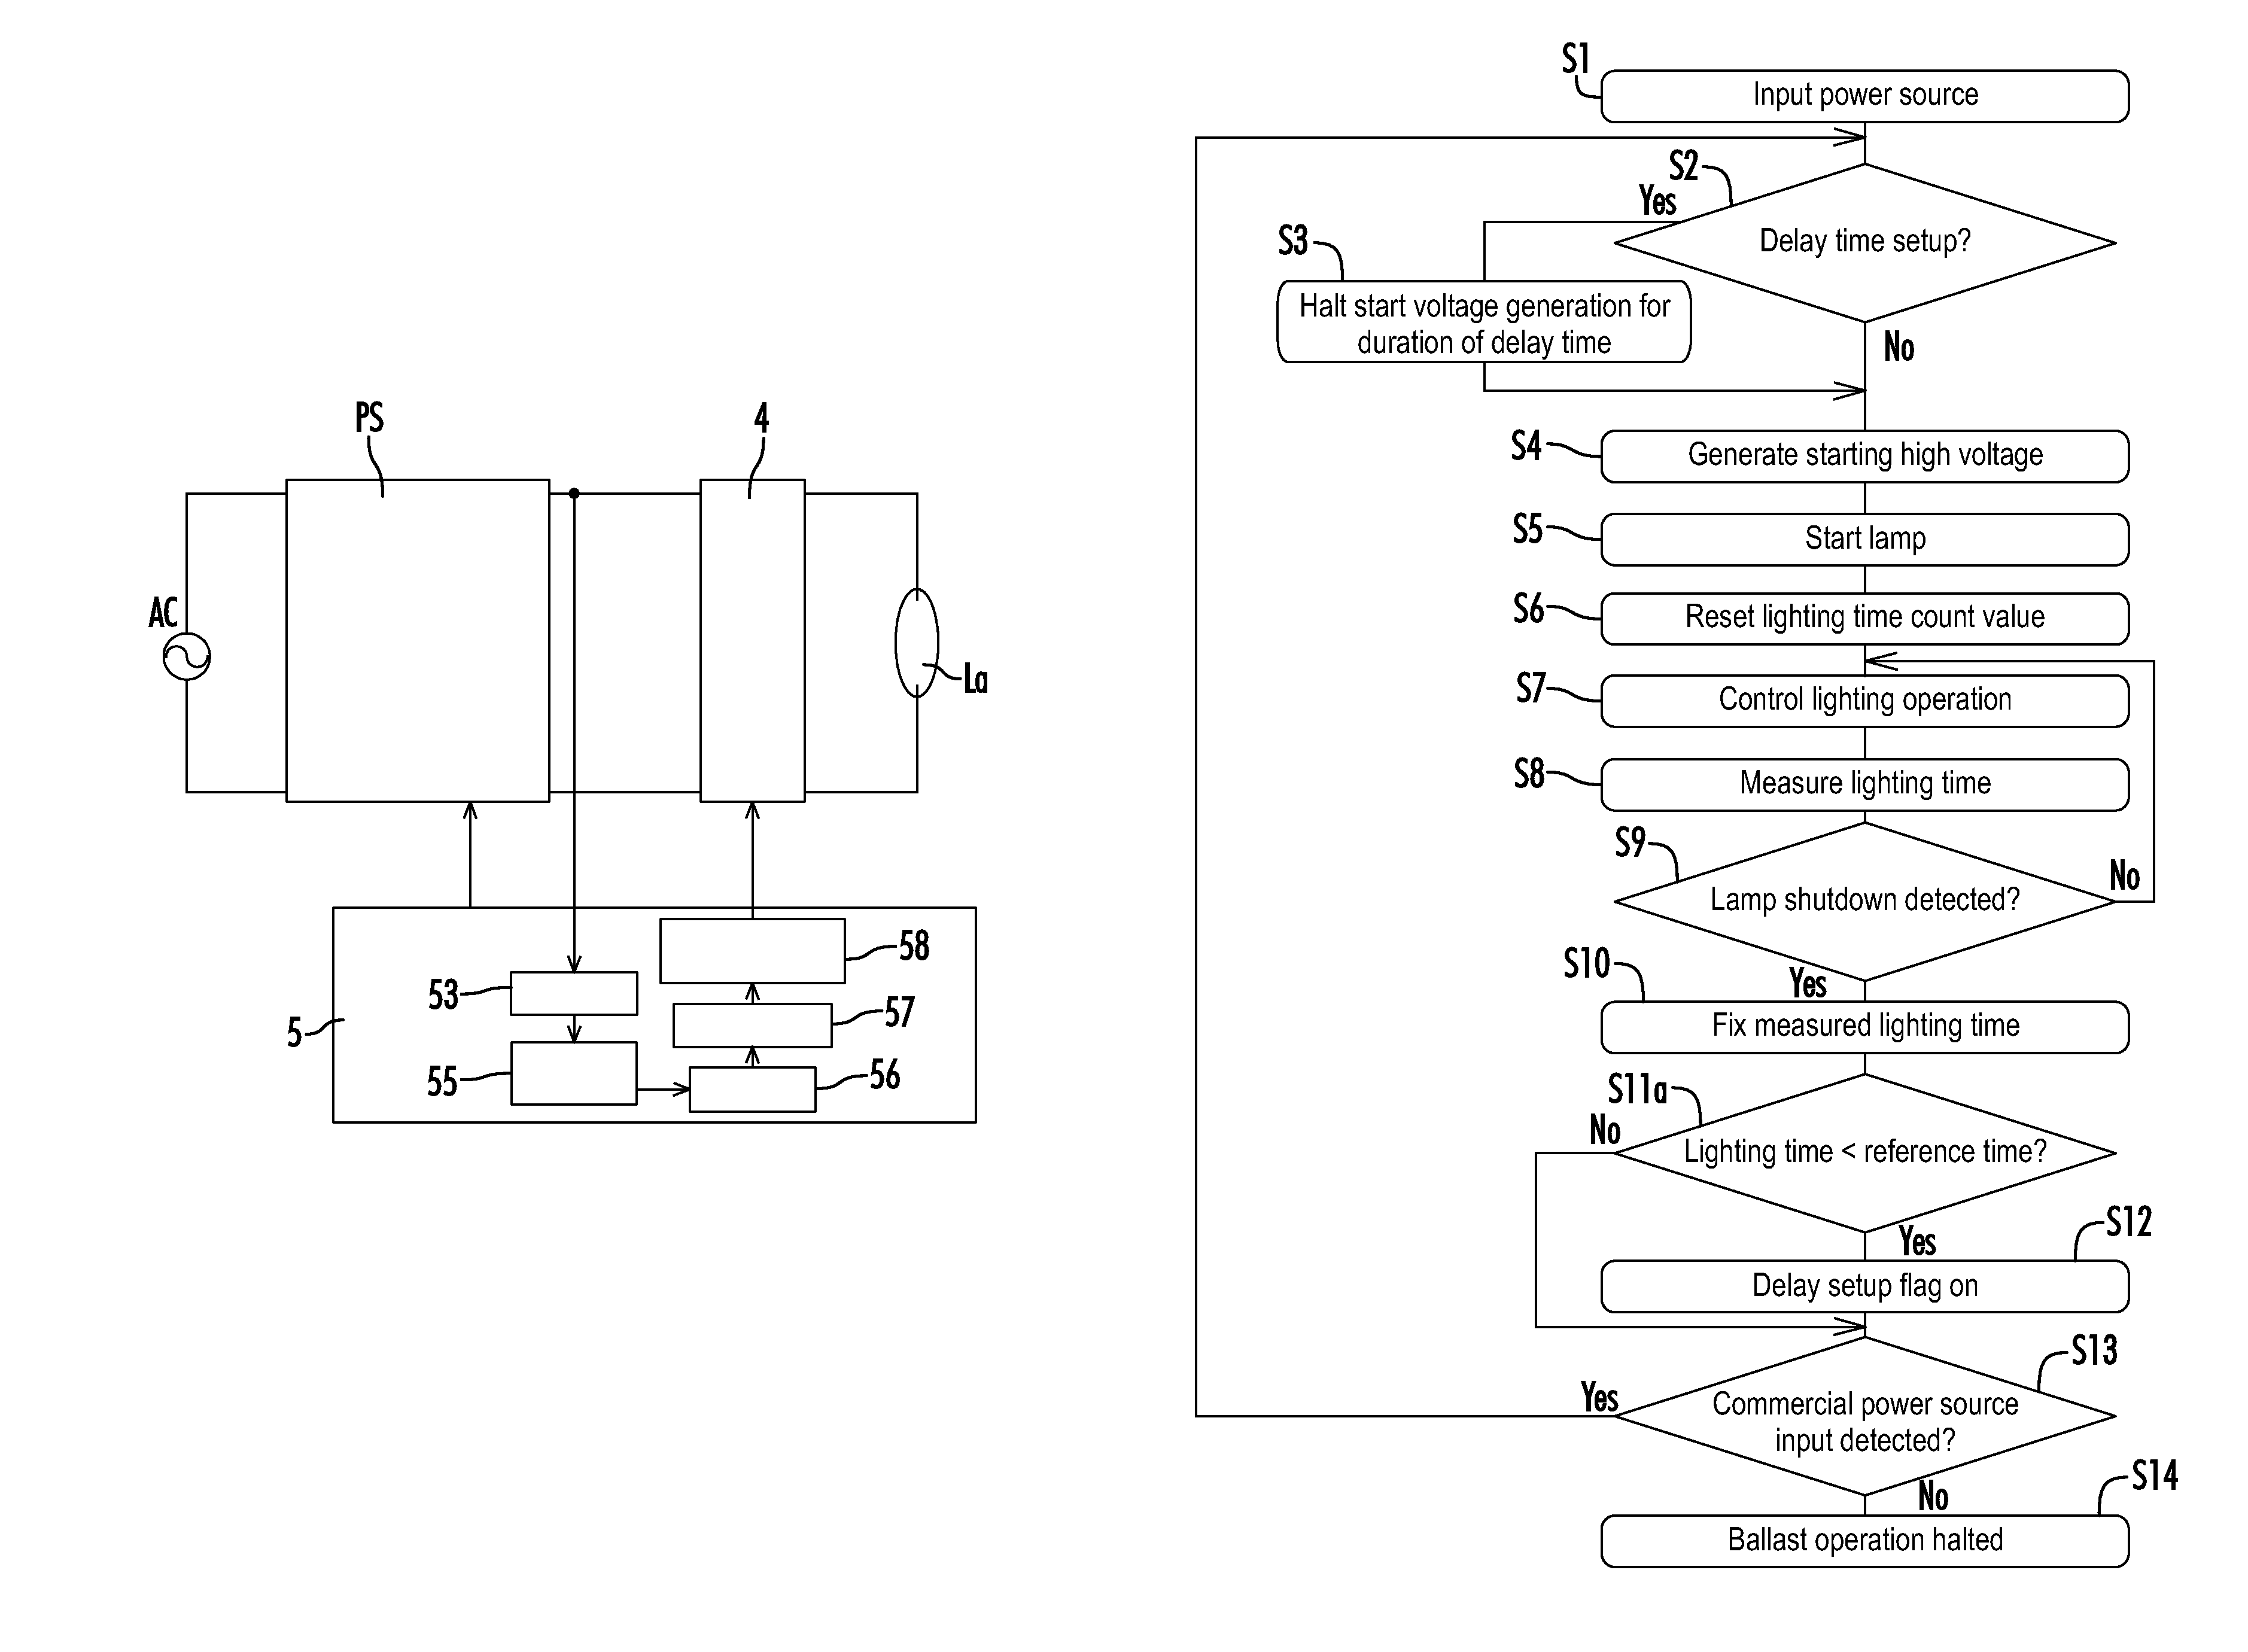
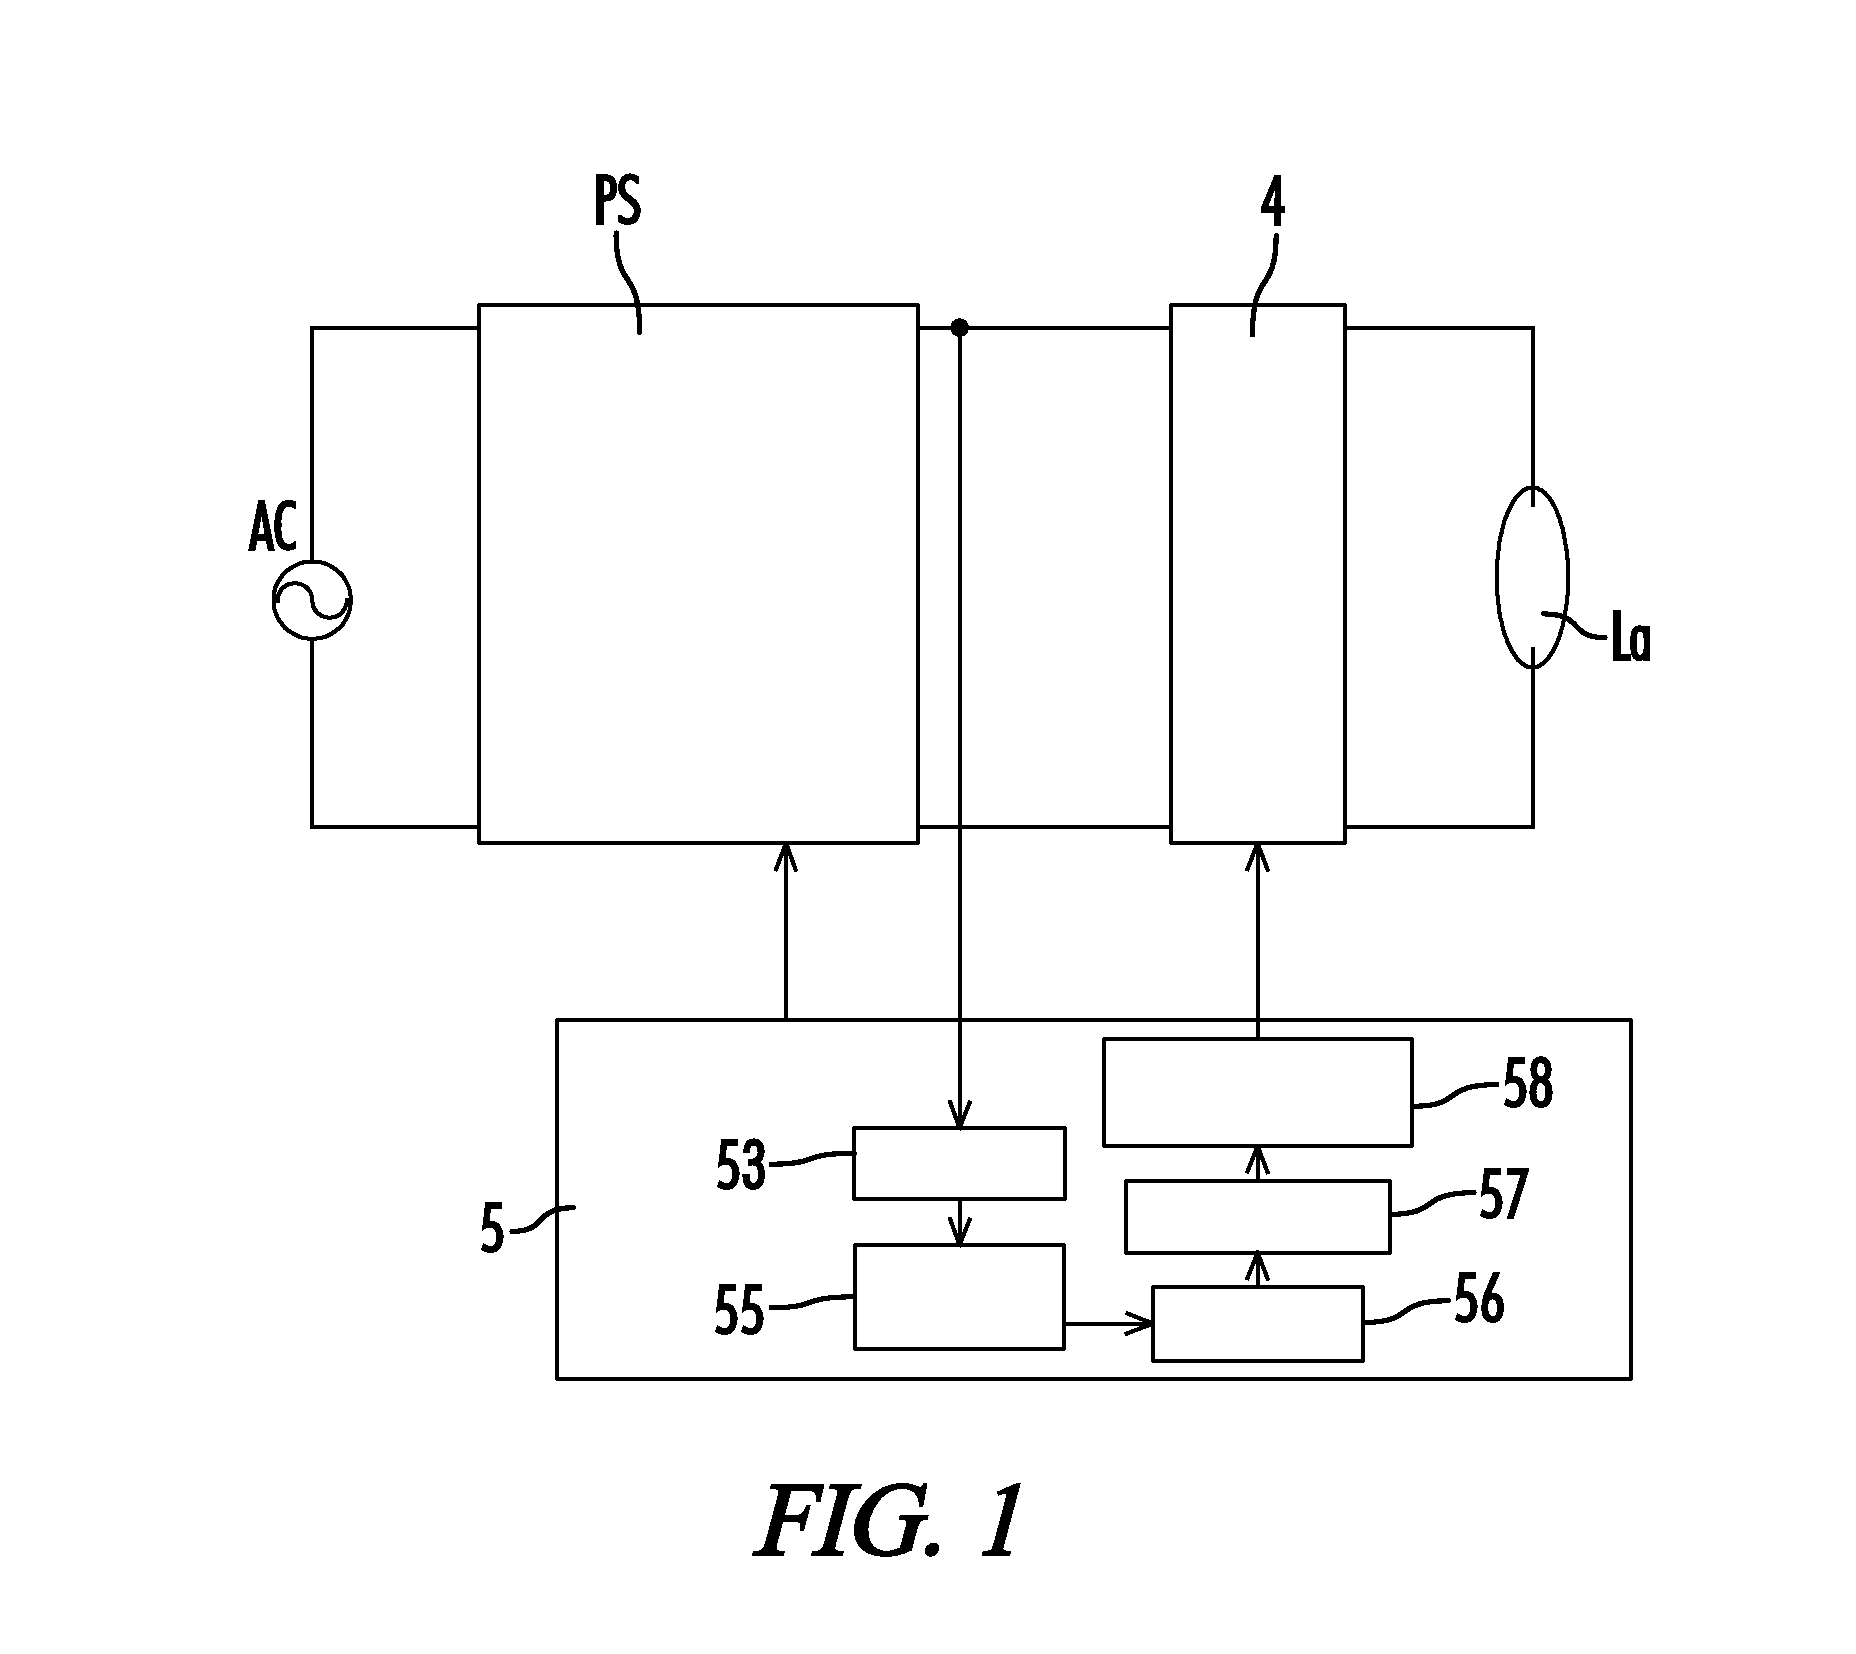
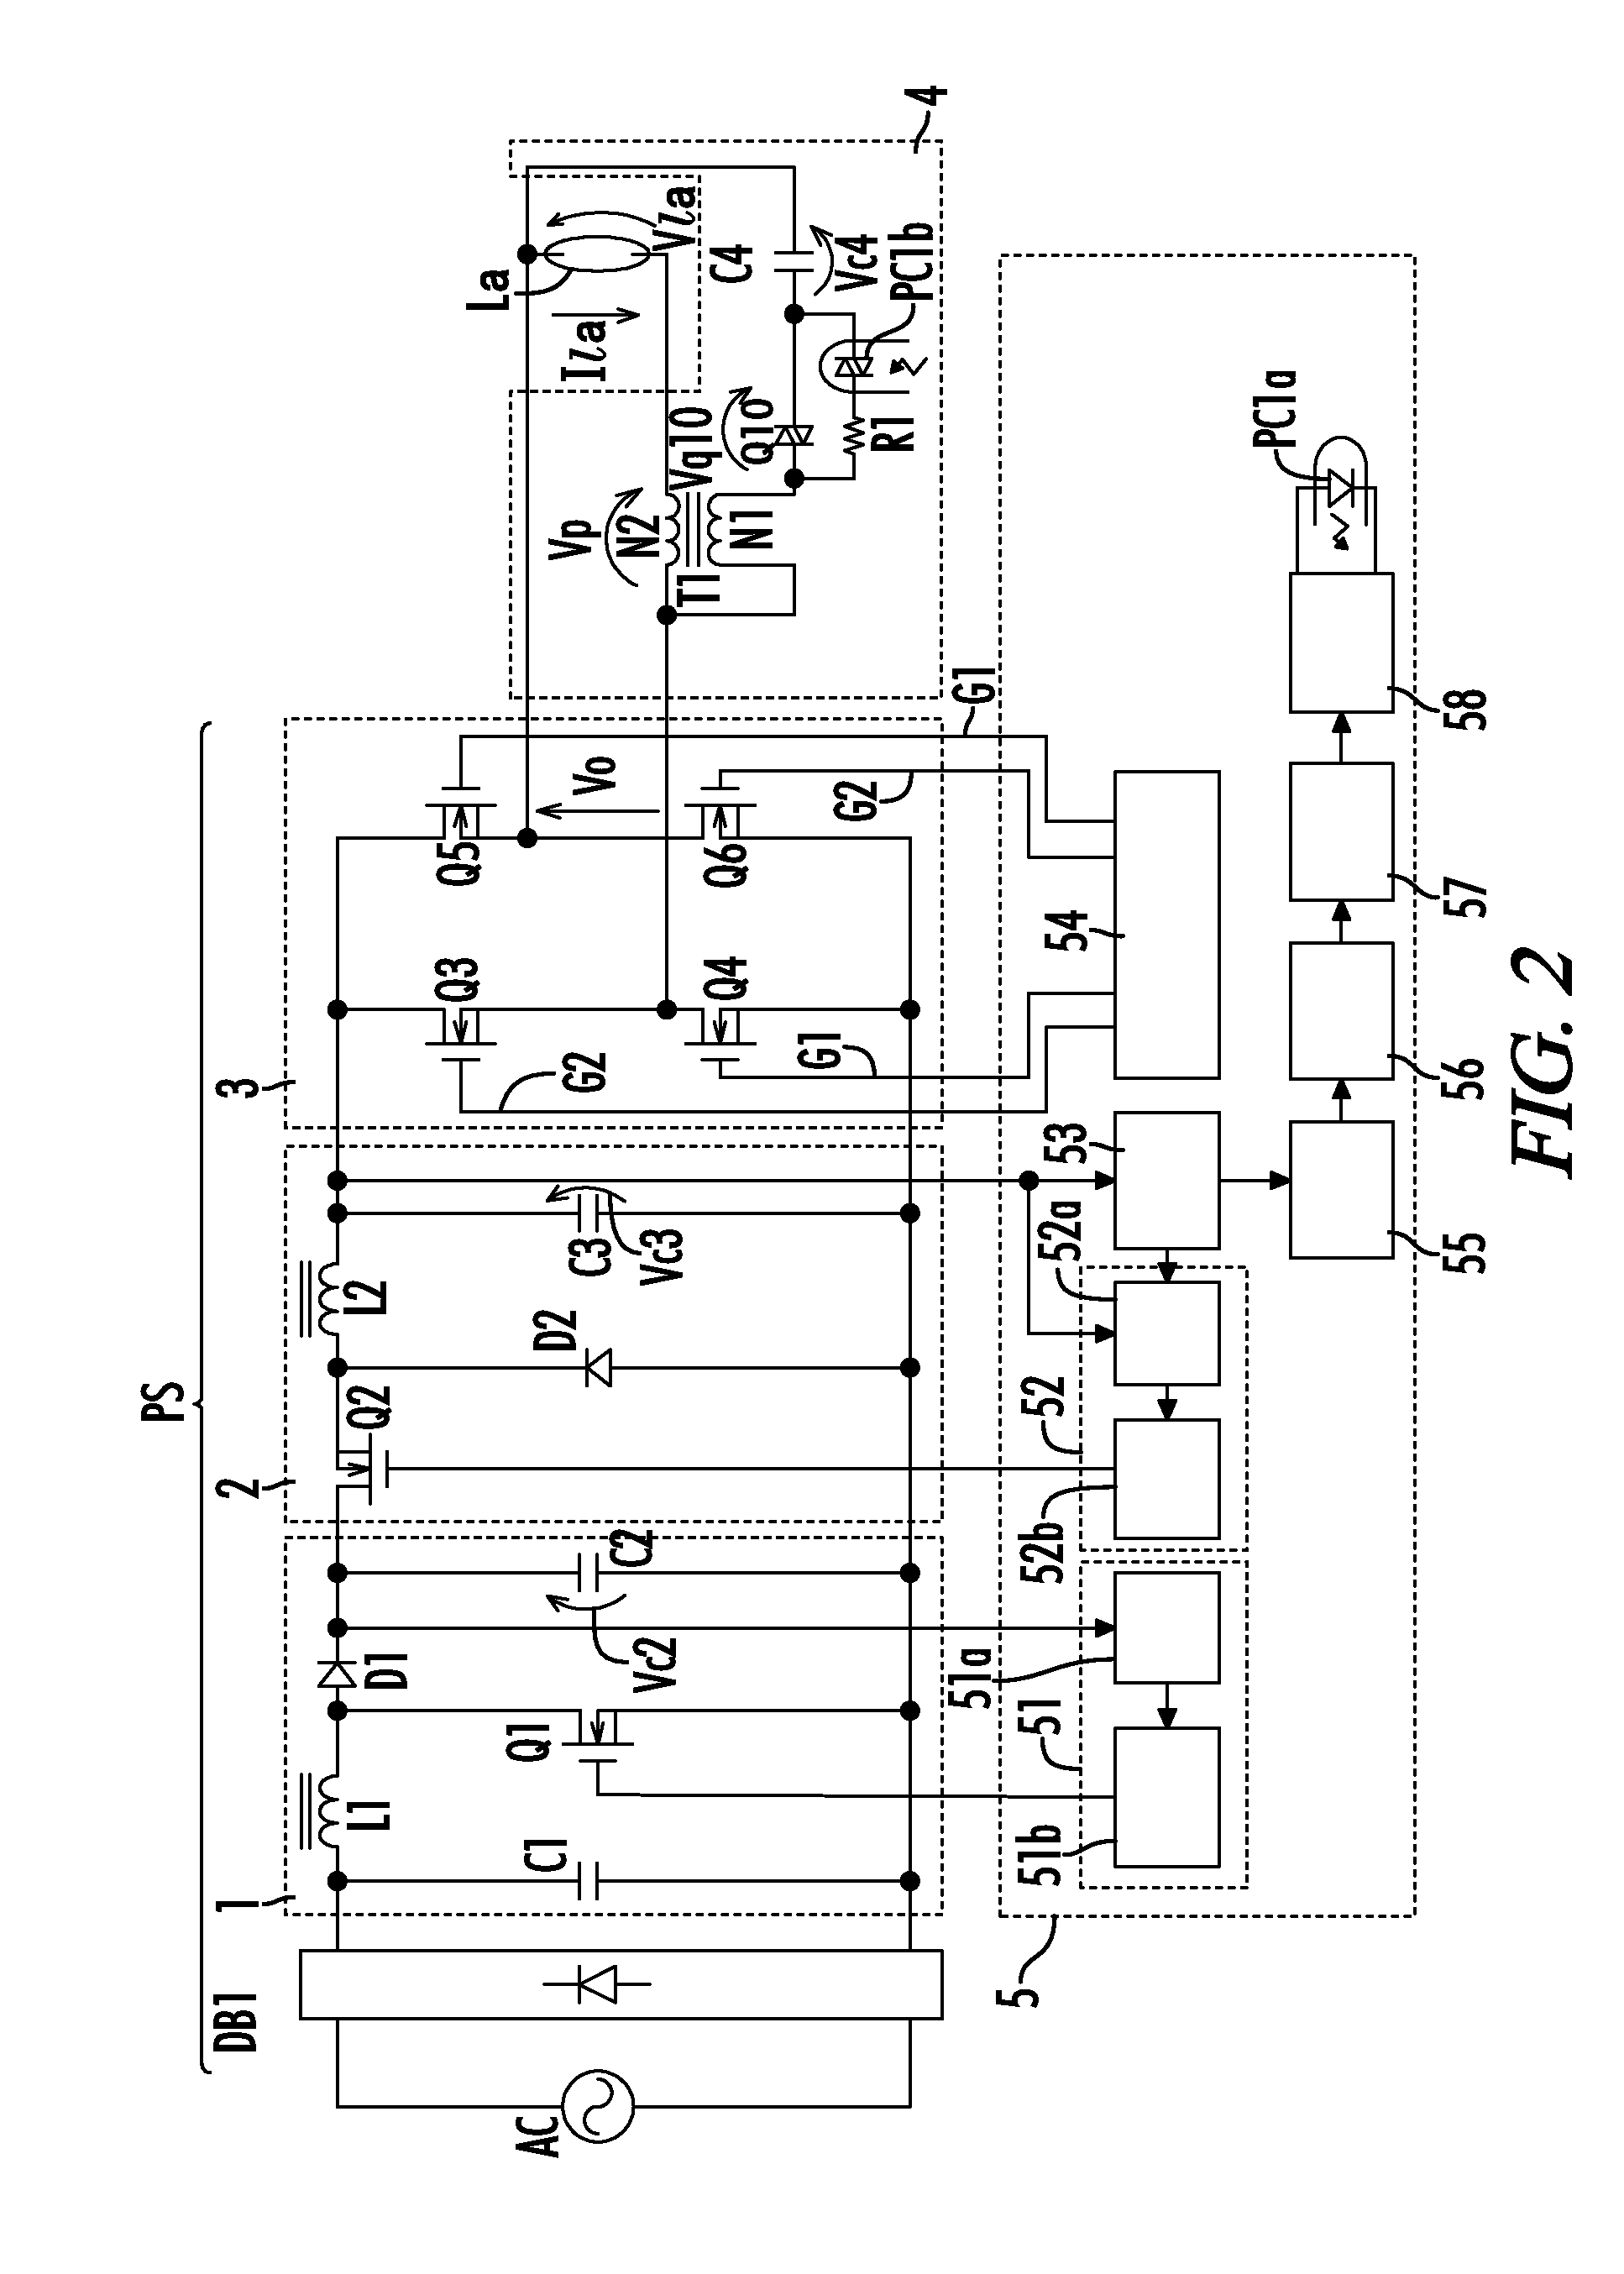
High pressure discharge lamp ballast, lighting device and lighting system
InactiveCN101815392ASmooth dischargeFully heatedElectrical apparatusElectric lighting sourcesFull bridgeLighting-up time
The invention relates to a high pressure discharge lamp ballast, a lighting device and a lighting system, which can meet an electrode require, adequately heat and form a stable discharge without making the circuit structure complex. The high pressure discharge lamp ballast (1) comprises a full-bridge circuit (11) which converts DC power into AC power, a startup circuit (12) which generates a startup high voltage for breaking down the lamp (DL) insulation, a buck chopper (13) which reduces the output voltage of a DC power supply (E) and outputting to the full-bridge circuit (11), a lamp ballast state detection unit (14) which detects the lamp (DL) ballast state, and a control circuit (15) which controls the full-bridge circuit (11) and the startup circuit (13). The control circuit (15) sets the lamp power supply during the electrode heating period when the lamp is started according to an accumulation ballast time detected by the lamp ballast detection unit (14).
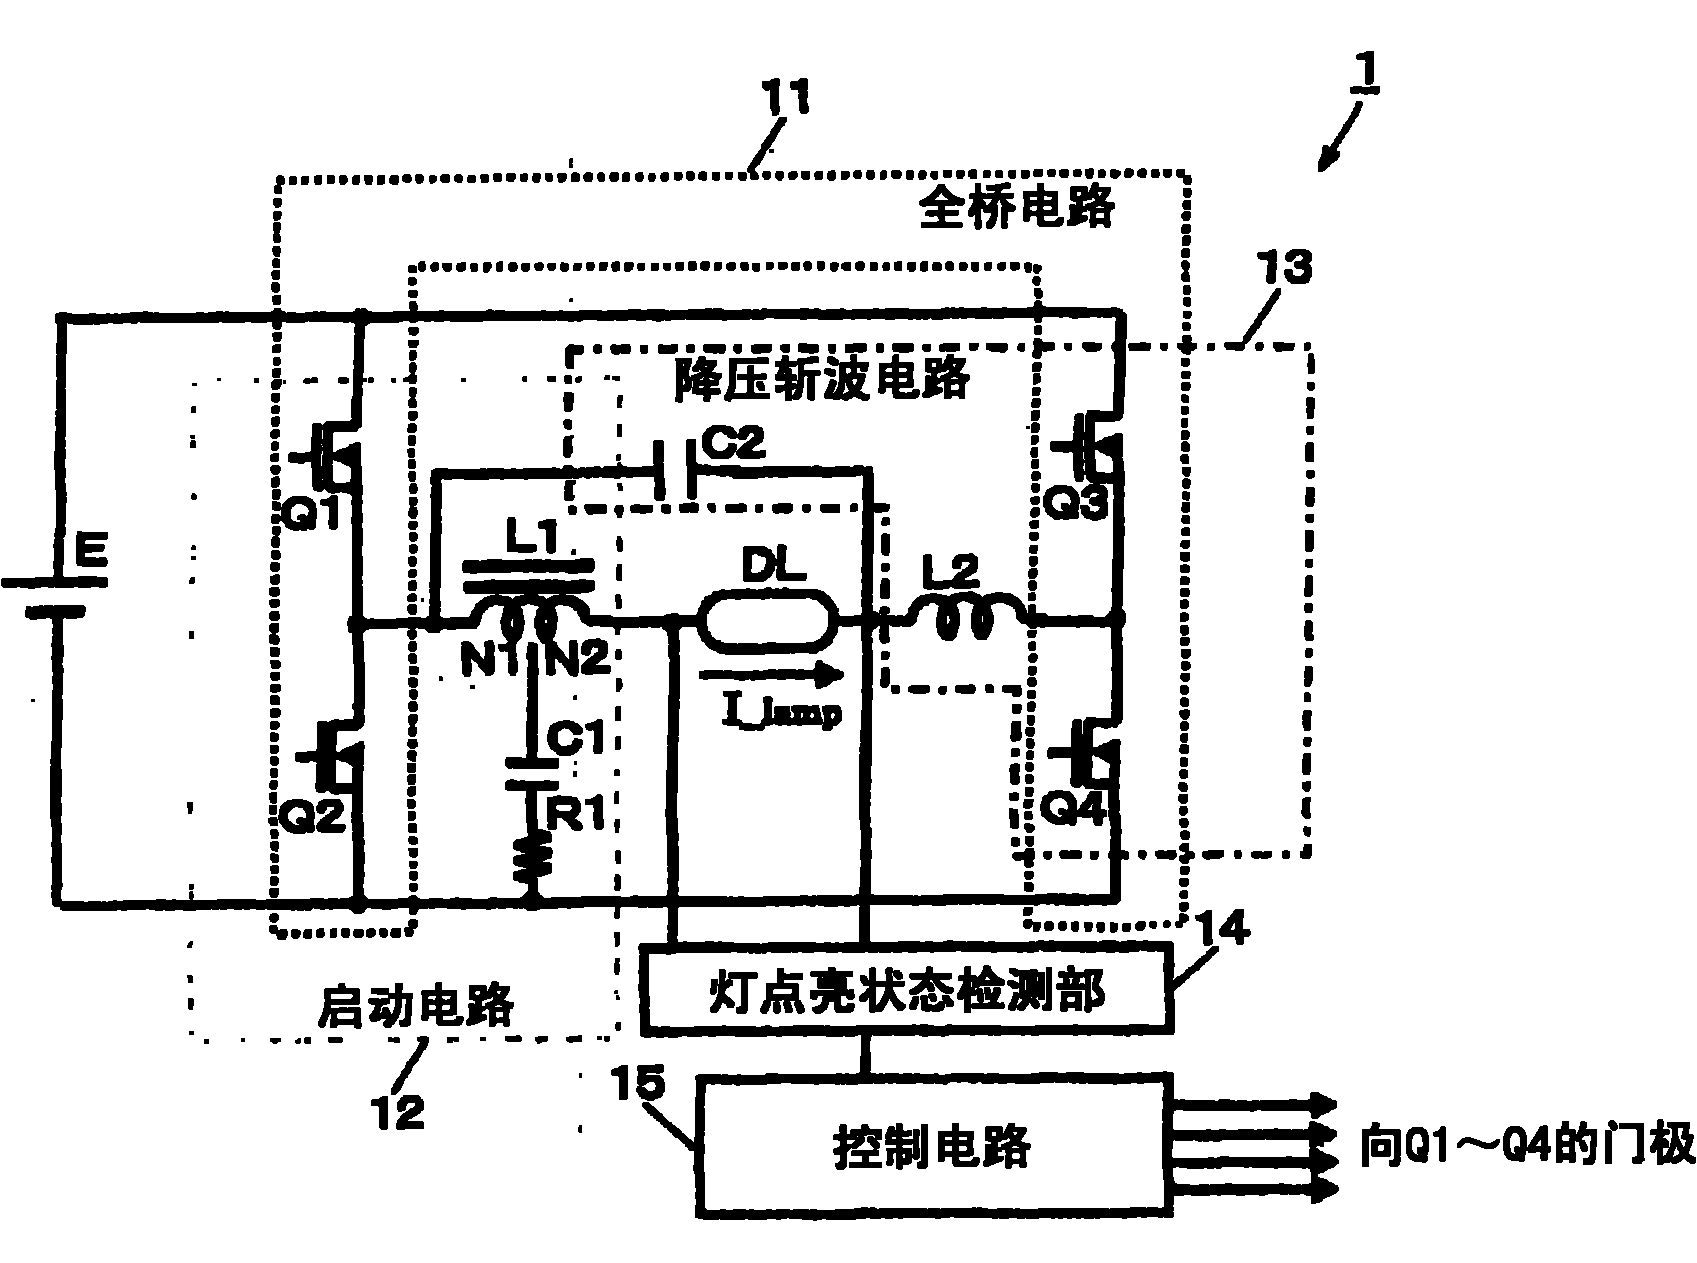

Owner:PANASONIC CORP
High-pressure discharge lamp ballast with rapid lamp restart circuit
InactiveUS8207690B2ReliablyReliable restartElectrical apparatusElectric light circuit arrangementDelayed timeHigh pressure
Owner:PANASONIC CORP
Brightness compensation method and compensation device of display panel and display device
ActiveCN110706637AIn line with the actual brightness attenuation lawFast compensationStatic indicating devicesLighting-up timeDisplay device
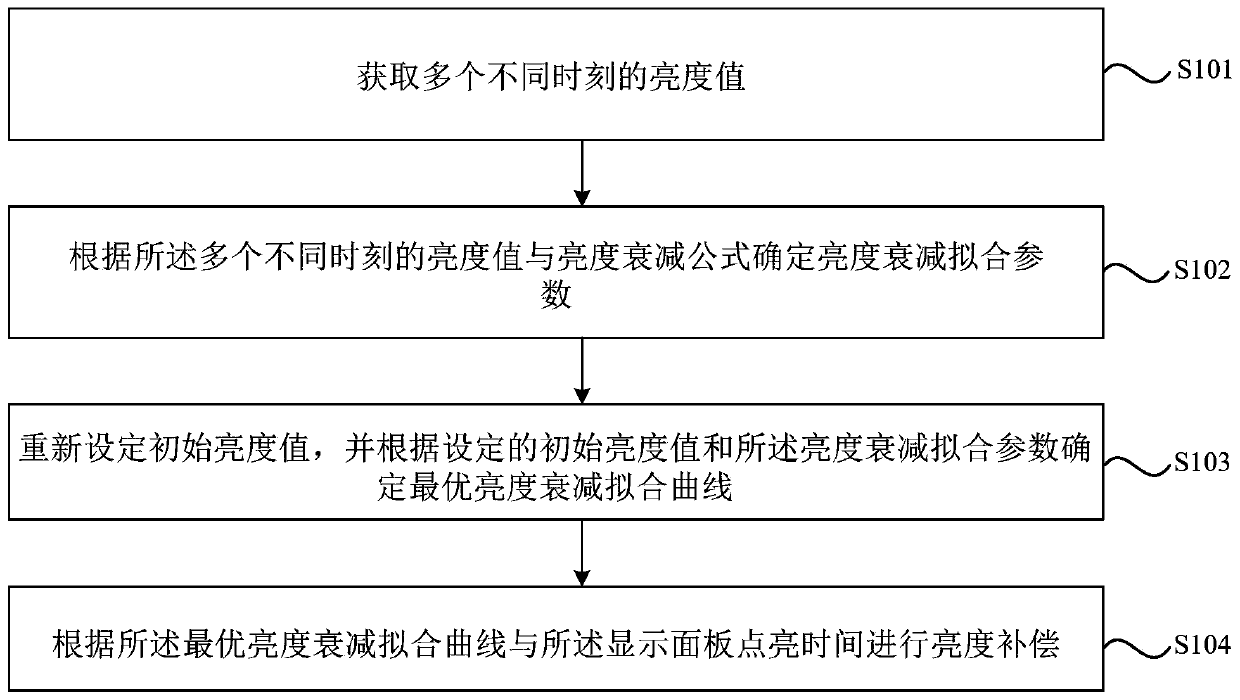
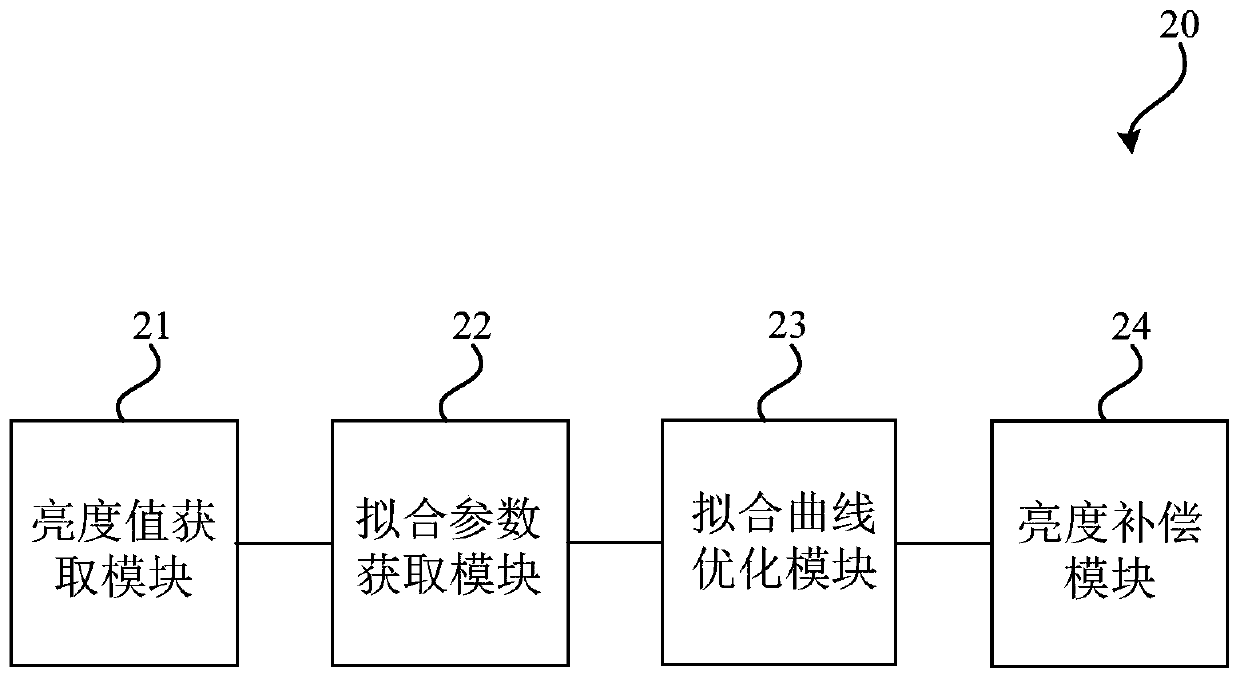
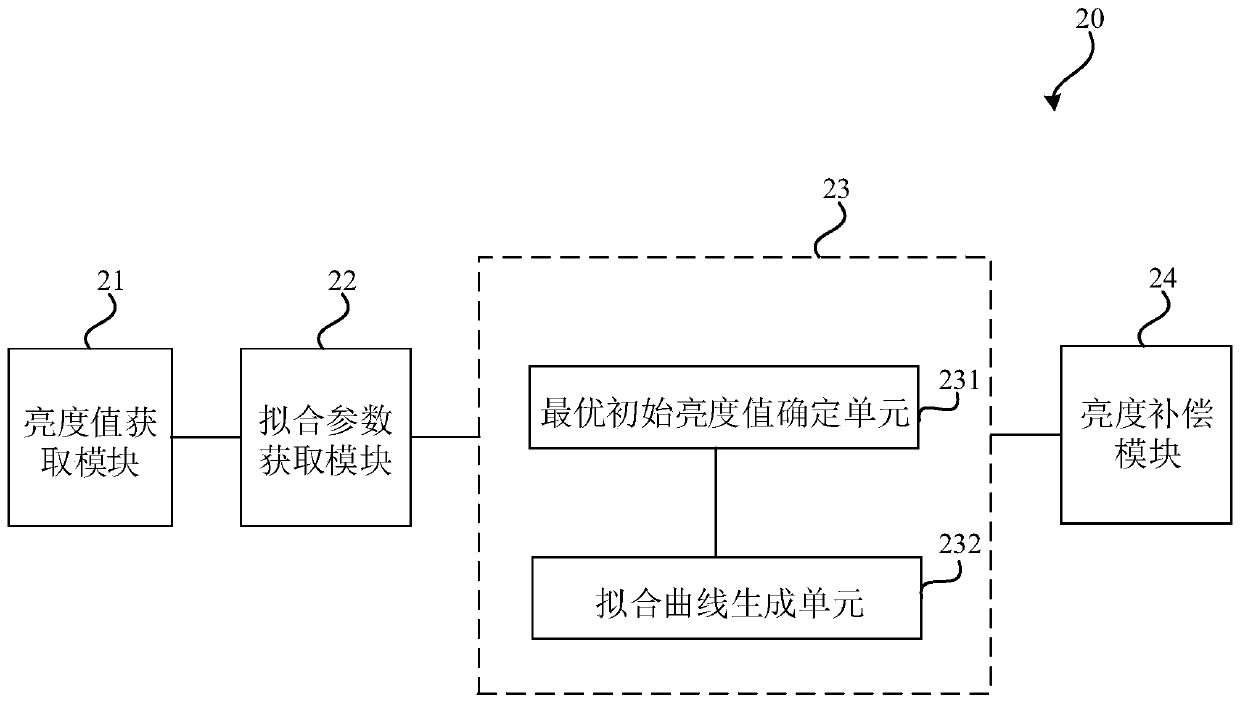
The embodiment of the invention discloses a brightness compensation method and device of a display panel and the display device. The brightness compensation method of the display panel comprises the steps of obtaining brightness values at multiple different moments; determining brightness attenuation fitting parameters according to the brightness values at the different moments and a brightness attenuation formula; resetting the initial brightness value, and determining an optimal brightness attenuation fitting curve according to the set initial brightness value and the brightness attenuationfitting parameter; and performing brightness compensation according to the optimal brightness attenuation fitting curve and the display panel lighting time. According to the technical scheme providedby the embodiment of the invention, the brightness attenuation of the display panel can be compensated accurately in real time.
Owner:KUNSHAN GO VISIONOX OPTO ELECTRONICS CO LTD
Intelligent traffic system and control method thereof
InactiveCN112396845AIncrease profitDetection of traffic movementIntelligent transportation system itsLighting-up time
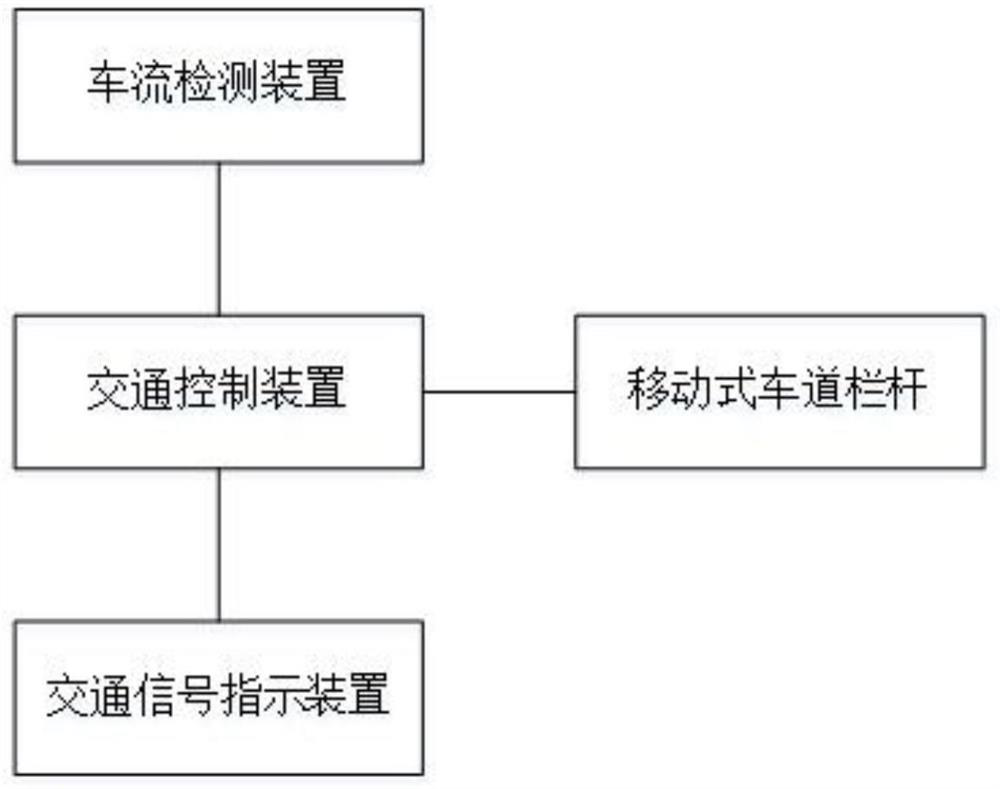
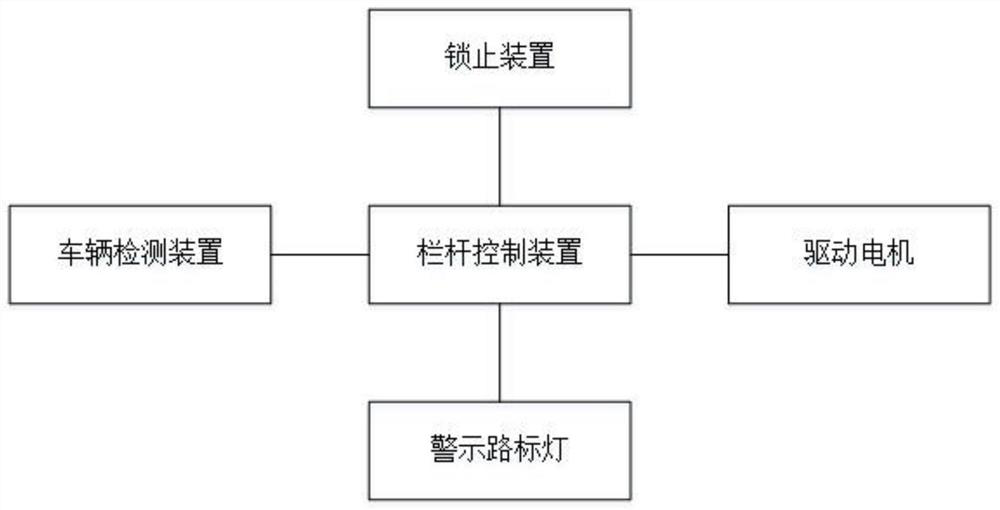
The invention discloses an intelligent traffic system and a control method thereof. The intelligent traffic system comprises a traffic flow detection device, a traffic control device and a traffic signal indicating device, wherein the traffic flow detection device is used for detecting the traffic flow of a target road in each time period; the traffic control device receives the detection result of the traffic flow detection device, generates a first instruction and a second instruction according to the detection result of the traffic flow detection device, is arranged on the road surface of the reversible lane, and is used for receiving the first instruction of the traffic control device and changing the reversible lane according to the first instruction; and the traffic signal indicatingdevice is arranged at the traffic intersection and is used for receiving the second instruction of the control device and adjusting the lightening time of each signal lamp according to the second instruction. The traffic flow is detected, and the lighting time of each signal lamp is adjusted according to the traffic flow, so that the utilization rate of the road traffic capacity can be enhanced.
Owner:王凯
Induction lamp control method and device
PendingCN107767699ALight up to achieveExtinguished achievedControlling traffic signalsAnti-collision systemsLighting-up timeControl engineering
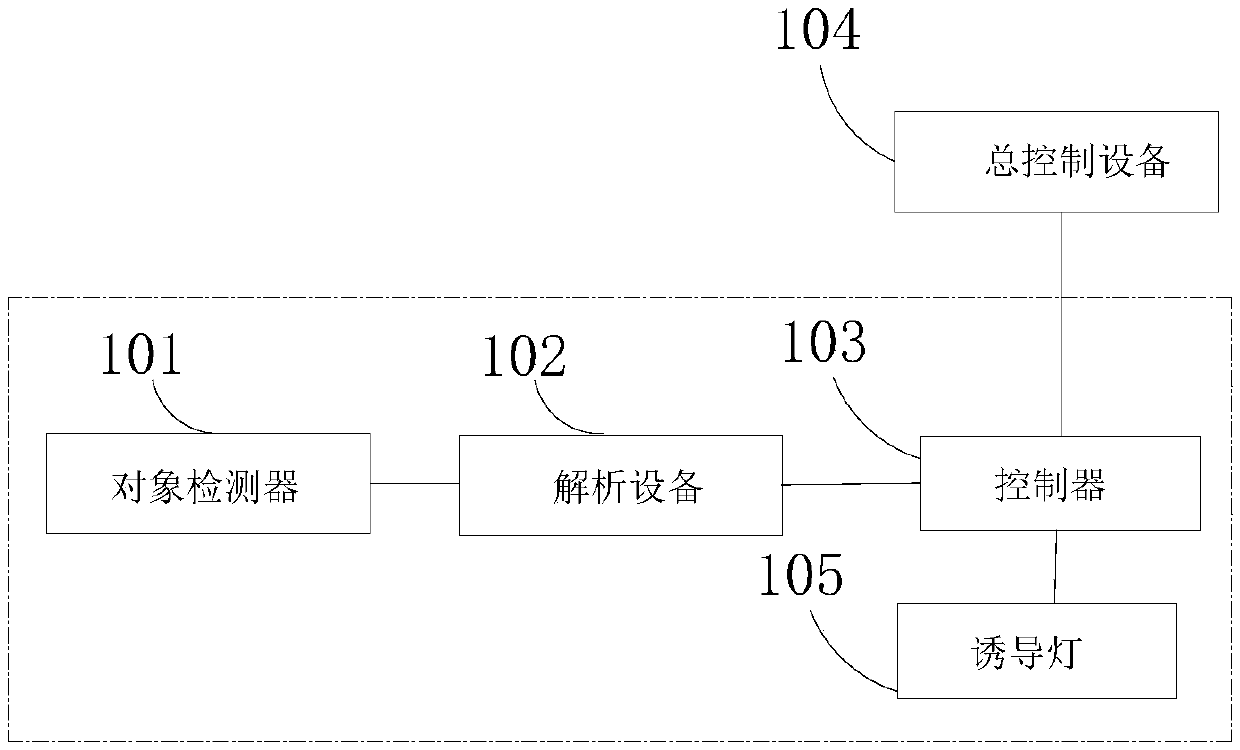
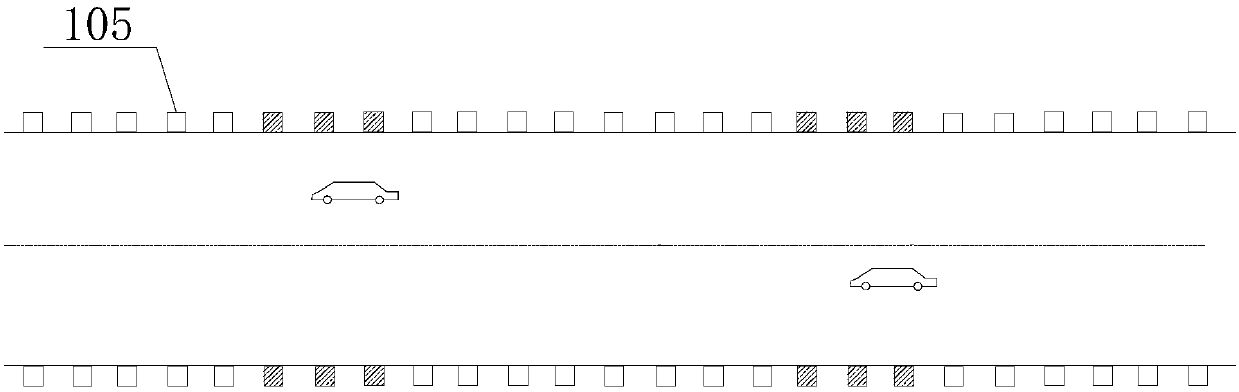
The invention provides an induction lamp control method and device and relates to the field of traffic control. The inductive lamp control method and device comprise that a plurality of object detectors detect vehicles or / and pedestrians moving on a road and generate a detection signal when the vehicles or / and pedestrians are detected; a controller receives first position information sent by an analysis device and the detection signal, switches on one or more induction lamps associated with the first position information after the detection signal is received, and switches off the one or moreinduction lamps associated with the first position information after a preset lighting time. Thus, the induction lamp are switched on along with the trajectories of the vehicles or / and pedestrians, and are switched off within preset lighting time after the vehicles or / and the pedestrians leave. Therefore, the induction lamp control method and device realize a cost-effective lighting facility and alighting control method, control the cost while providing lighting for vehicles and pedestrians, and are flexible to control.
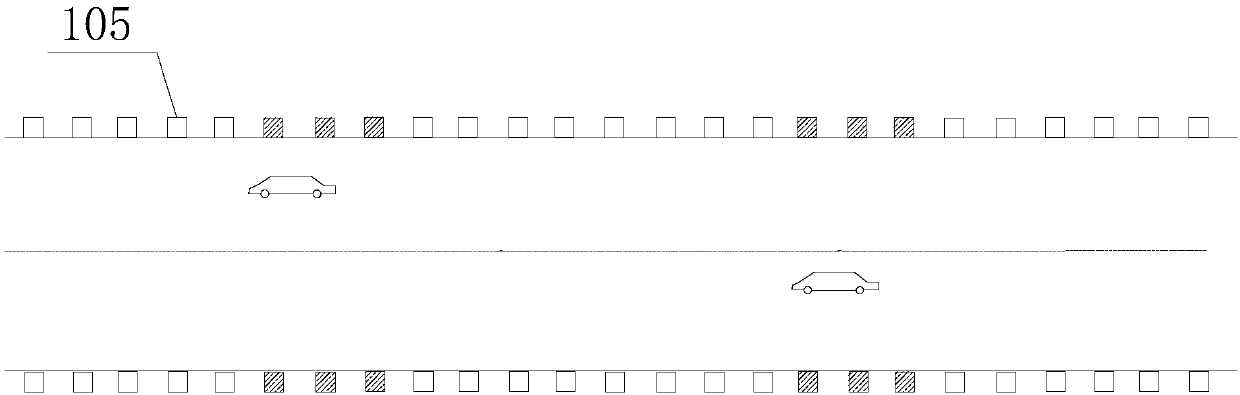
Owner:HANGZHOU BODA WEIYE PUBLIC SAFETY TECH CO LTD
Method and device for controlling street lamp, street lamp and readable storage medium
ActiveCN110856324AIncrease flexibilityExtended service lifeElectrical apparatusEnergy saving control techniquesLighting-up timeElectric energy
The invention relates to a method and a device for controlling a street lamp, the street lamp and a readable storage medium. The method is applied to the street lamp. Firstly, the street lamp acquiresthe light on condition of vehicles passing under the street lamp from the first preset time, then the appropriate lighting time of the street lamp is determined in accordance with the light on condition of the vehicles, and finally the street lamp is controlled to be lit on according to the appropriate lighting time. Therefore, the lighting time of the street lamp is no longer fixed and is determined according to the light on situation of the vehicles actually passing under the street lamp and thus flexibility of the lighting time of the street lamp is improved. Meanwhile, when the driver ofthe vehicle needs the auxiliary lighting of the street lamp, the street lamp is lit so that the lighting service capability of the street lamp to the vehicle is improved. In addition, when the driverof the vehicle does not need the auxiliary lighting of the street lamp, the street lamp is in the off state, thus avoiding the waste of electric energy by the street lamp and prolonging the service life of the street lamp.
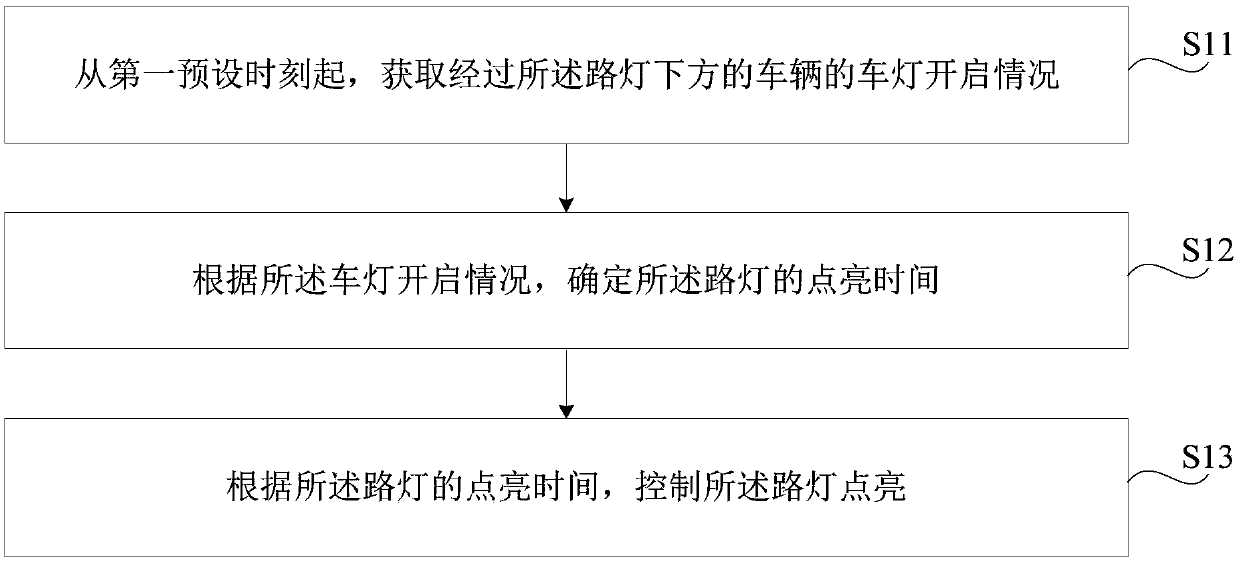
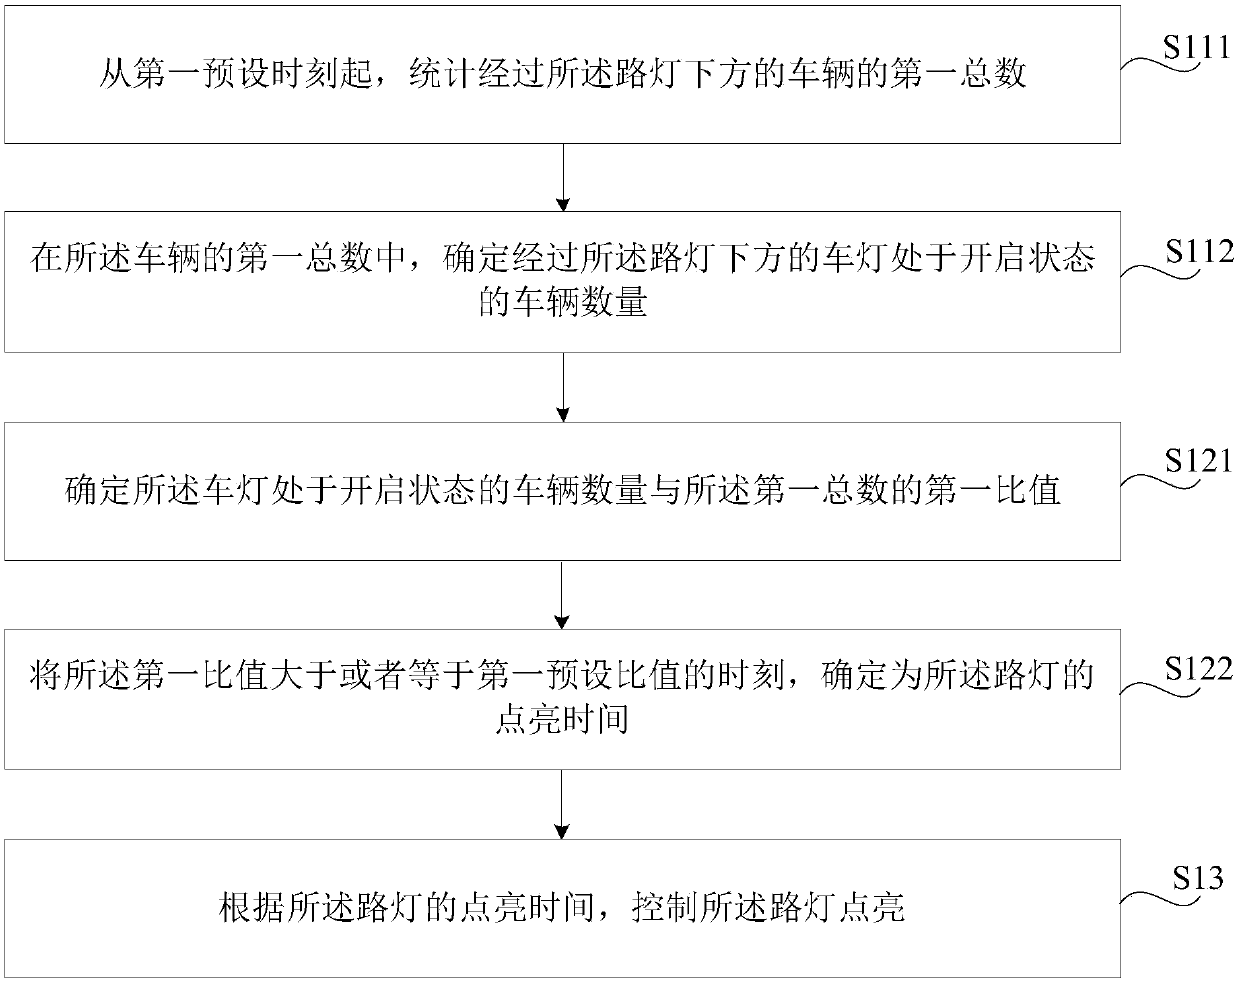
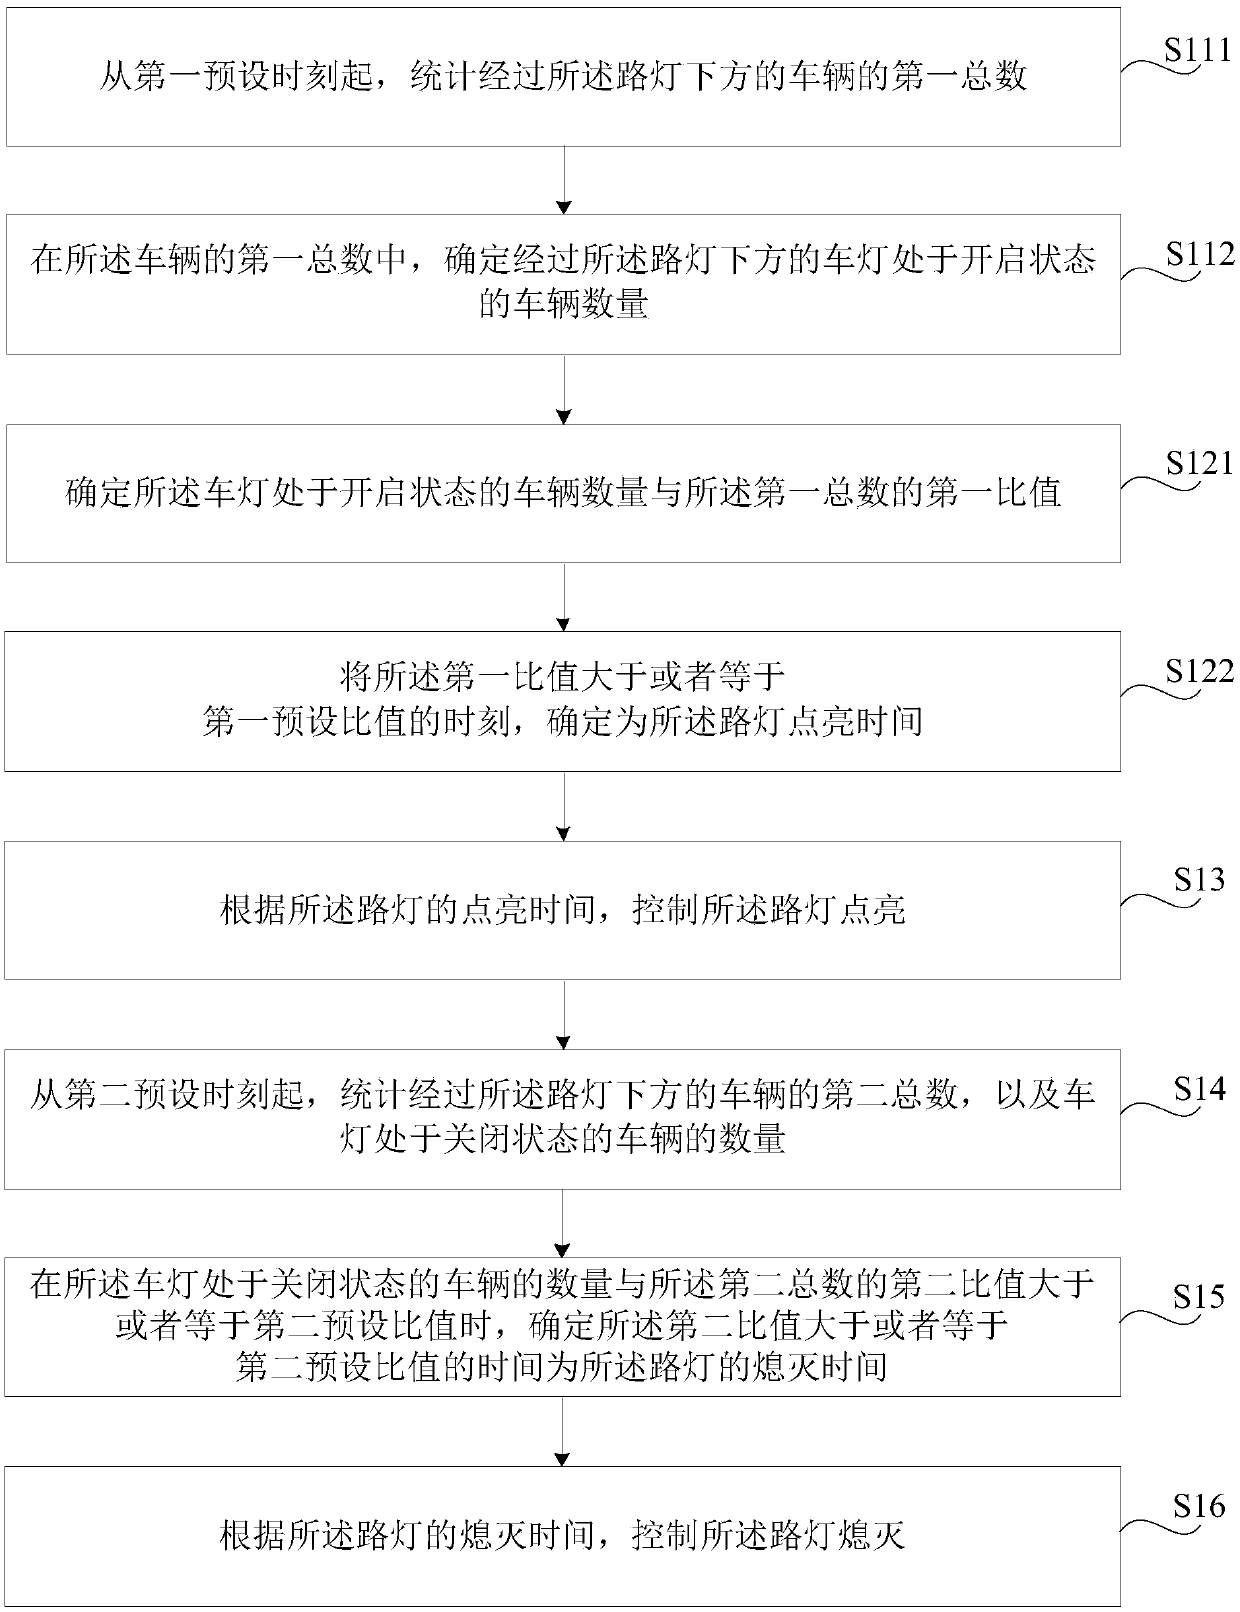
Owner:DONGXU OPTOELECTRONICS TECH CO LTD
Vehicular lamp, cold cathode fluorescent lamp lighting apparatus, and cold cathode fluorescent lamp lighting method
InactiveUS20050248282A1Convenient lightingAvoid damageElectrical apparatusElectric light circuit arrangementElectricityLighting-up time
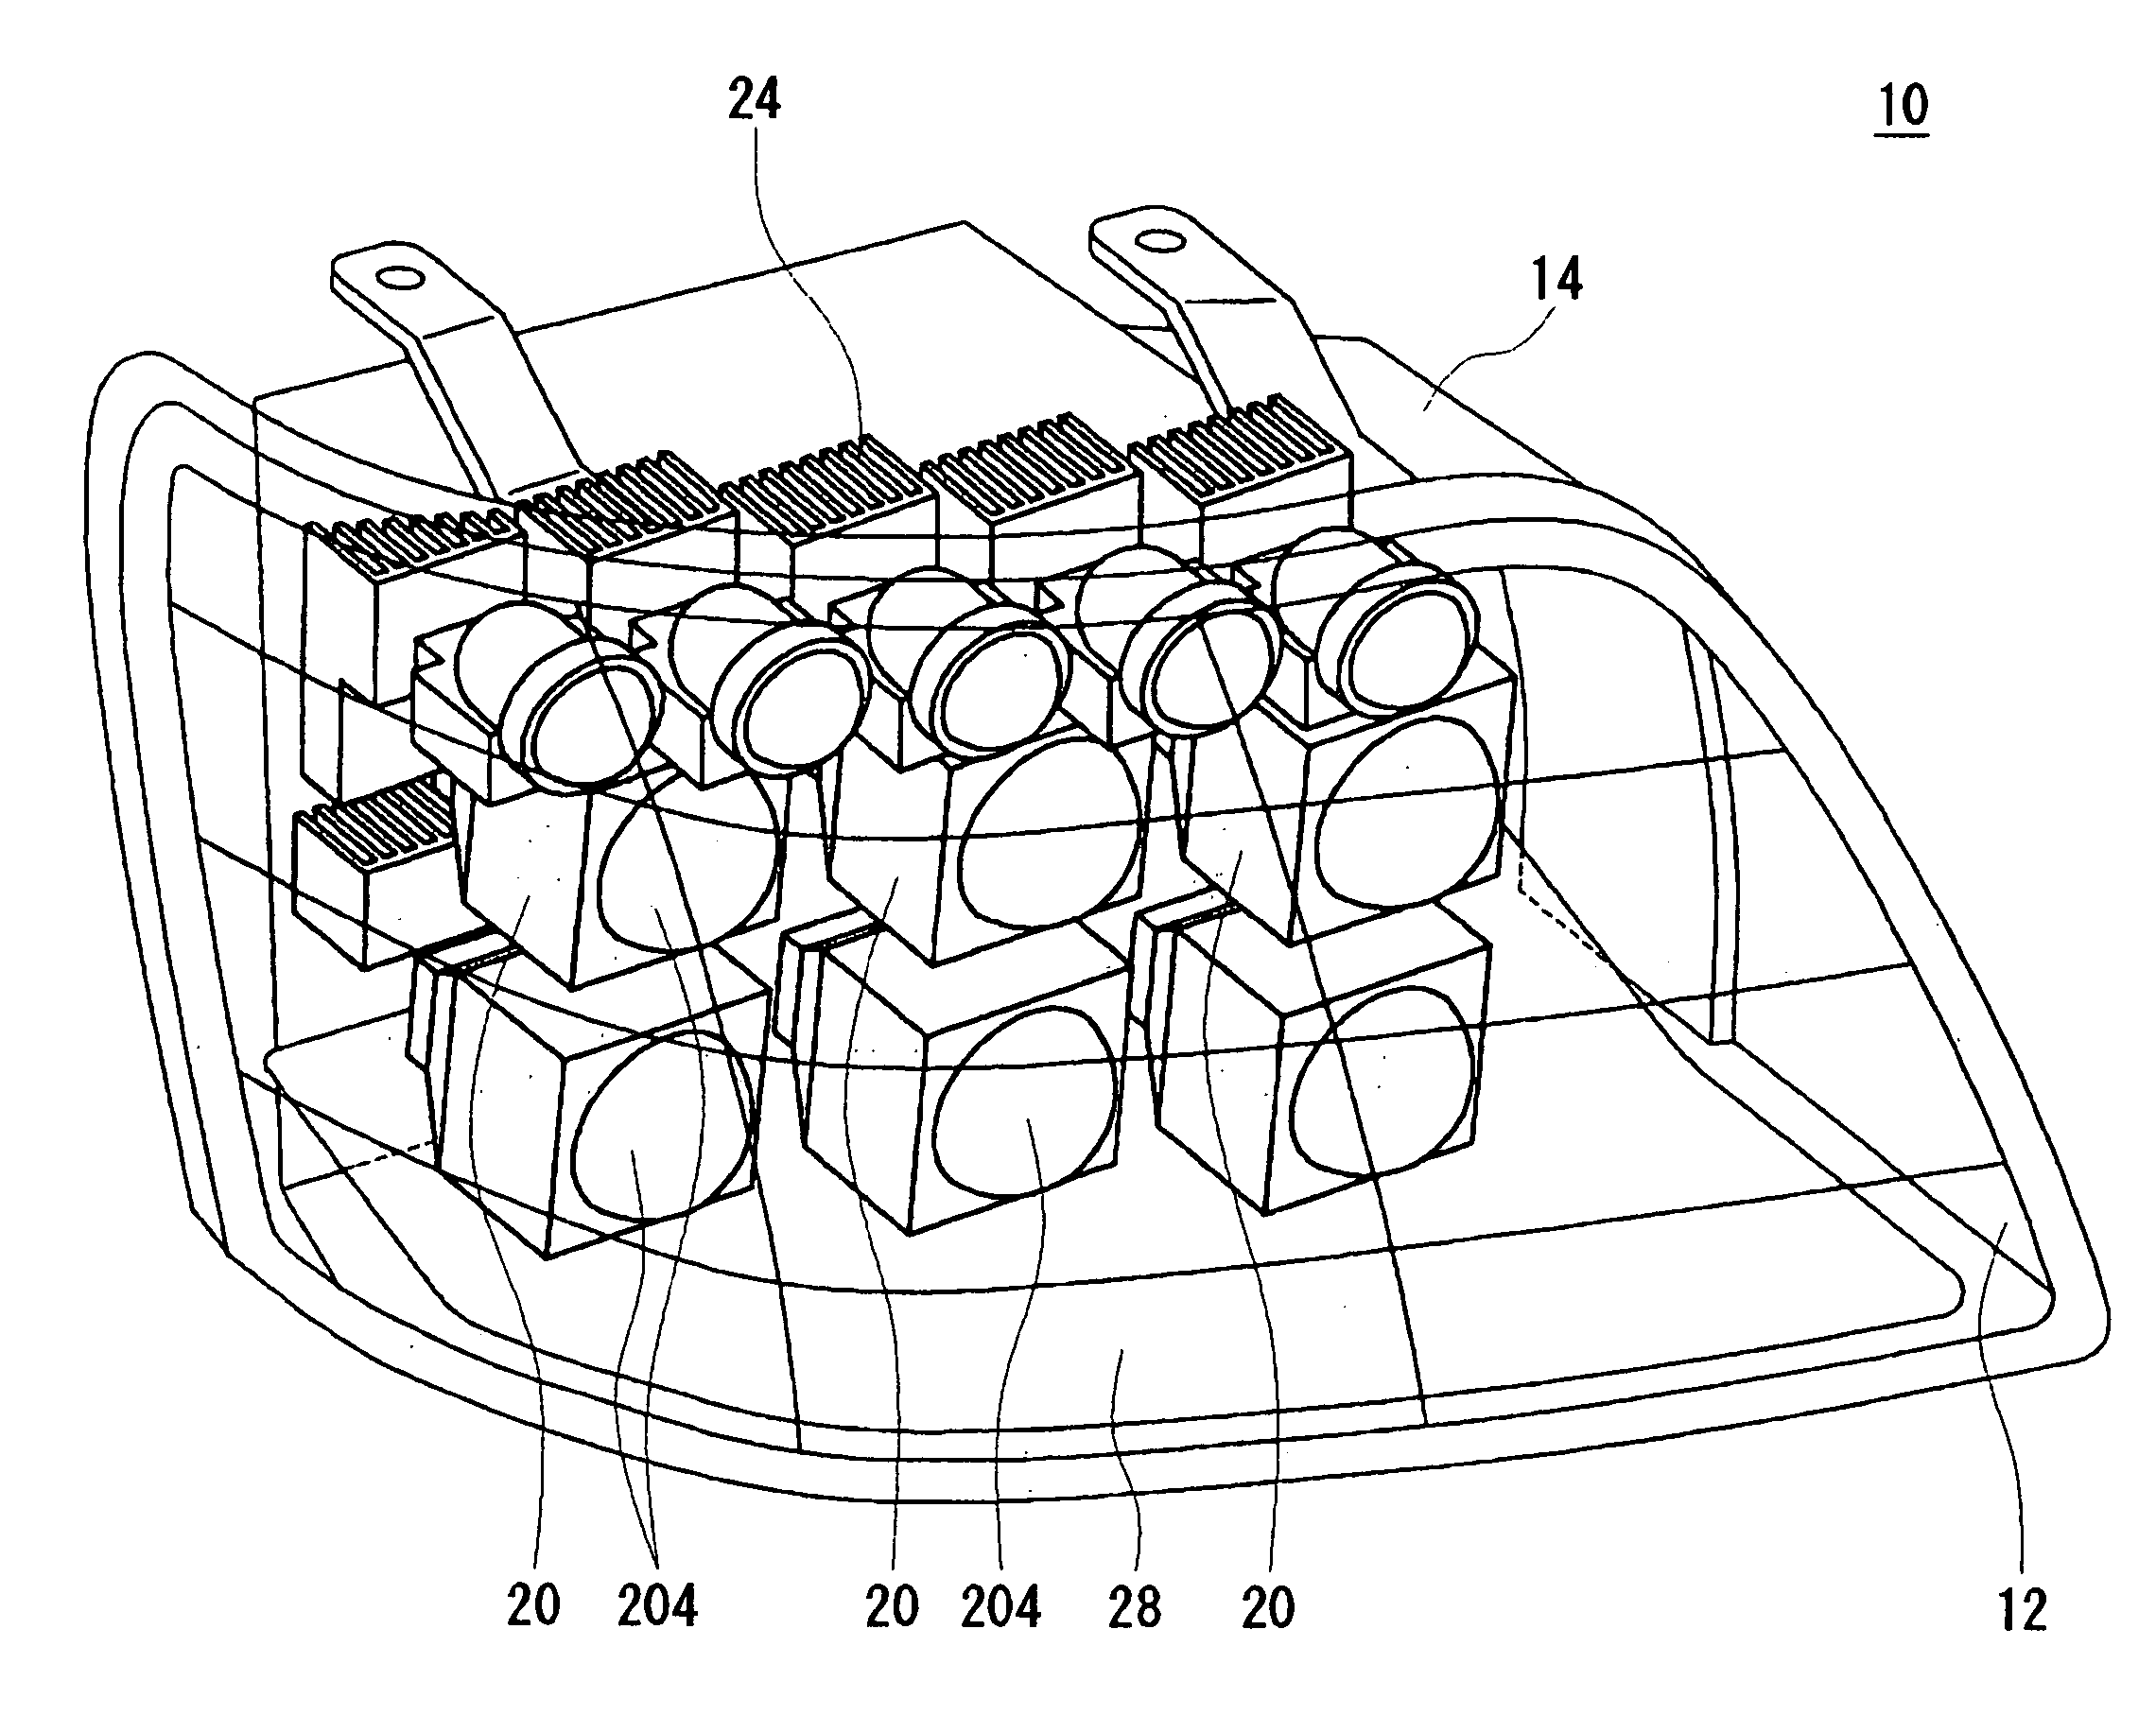
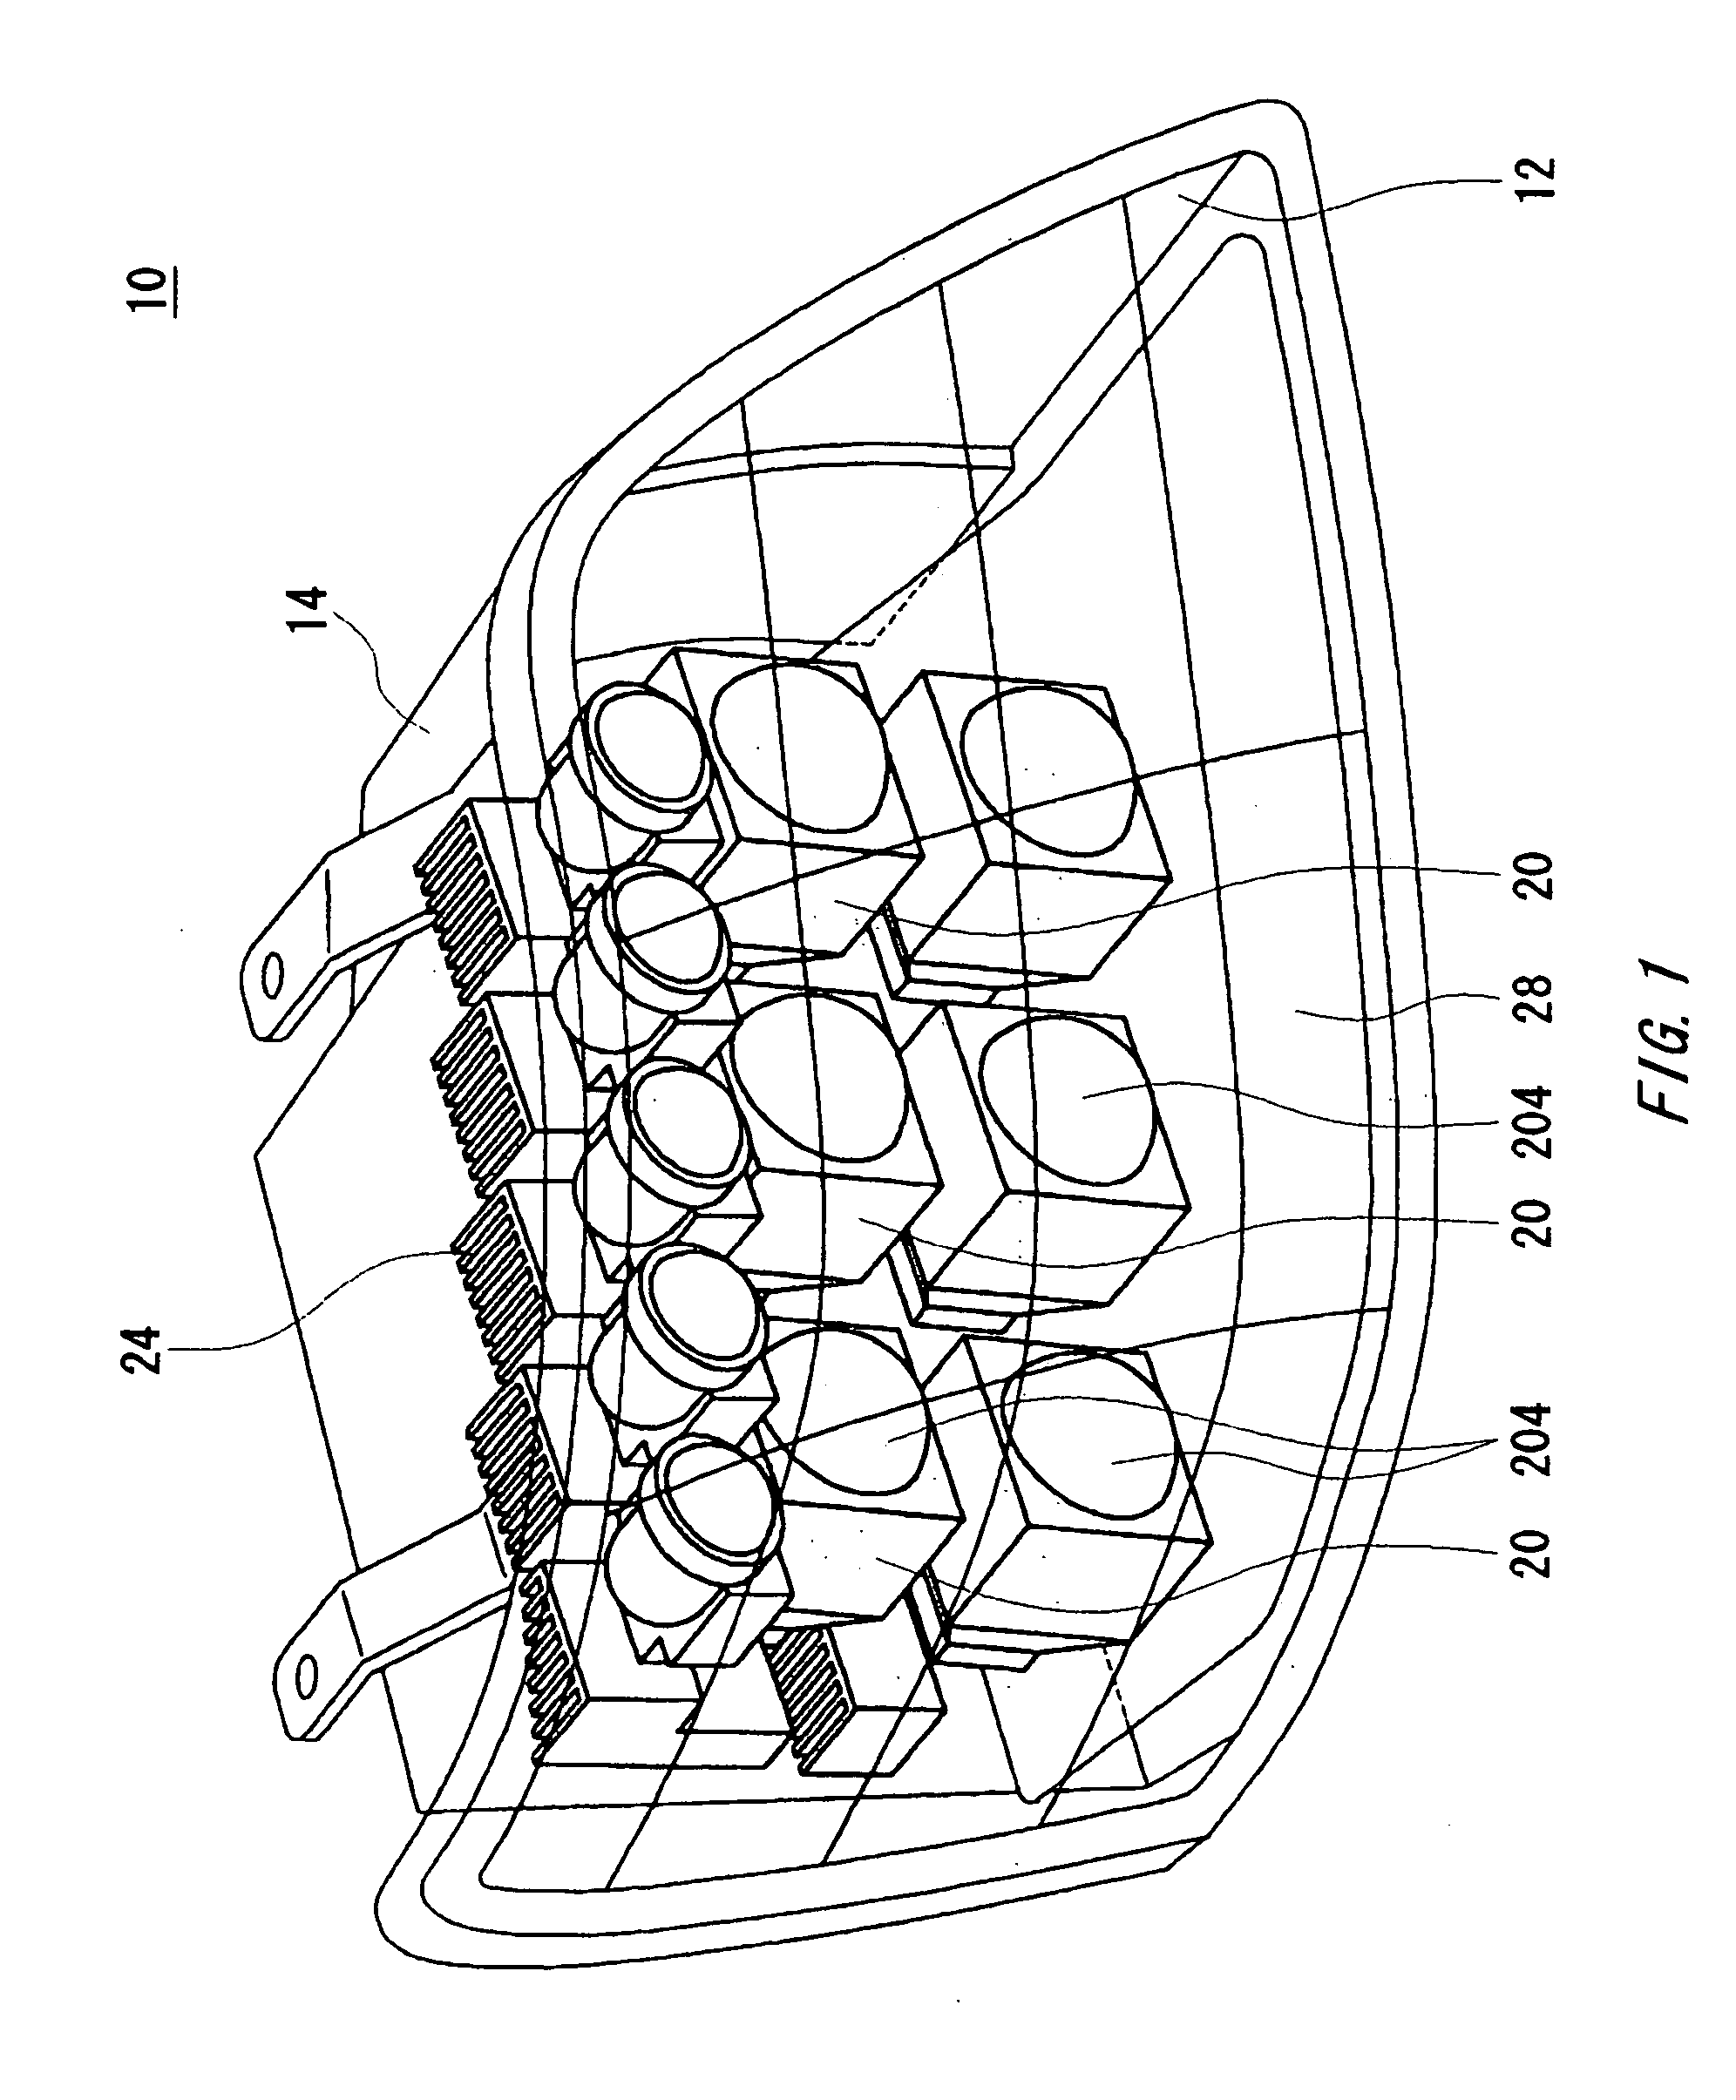
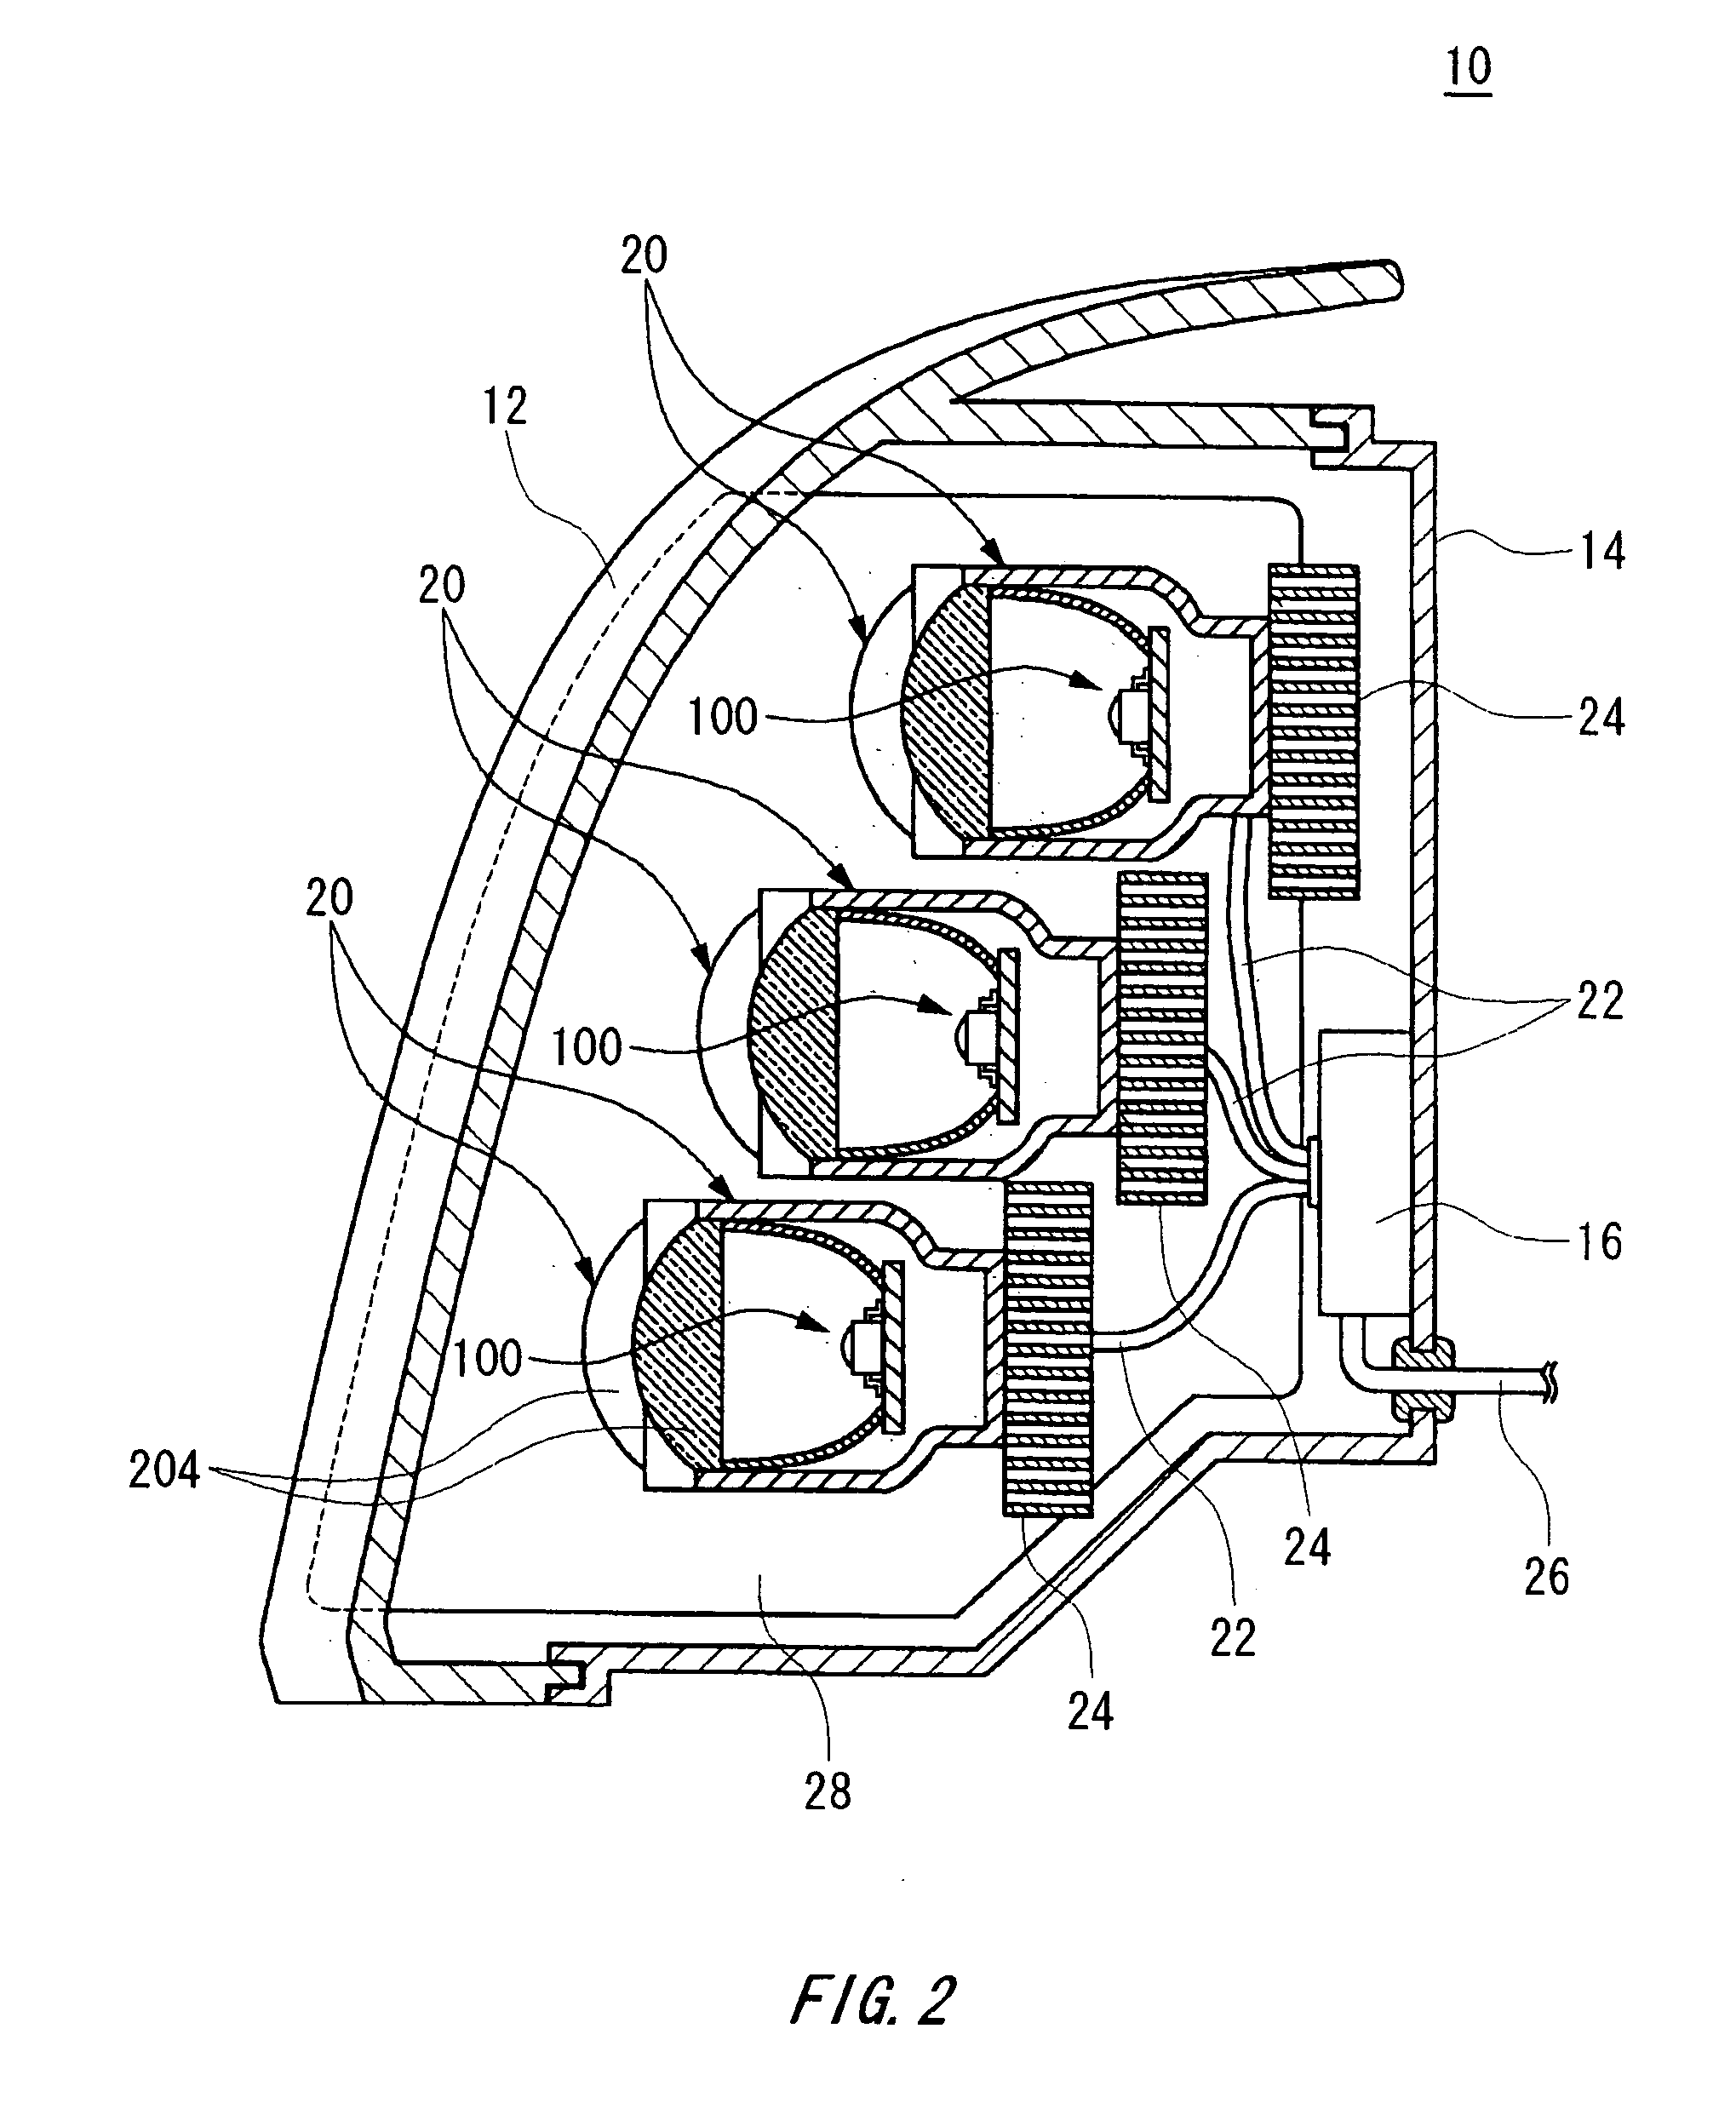
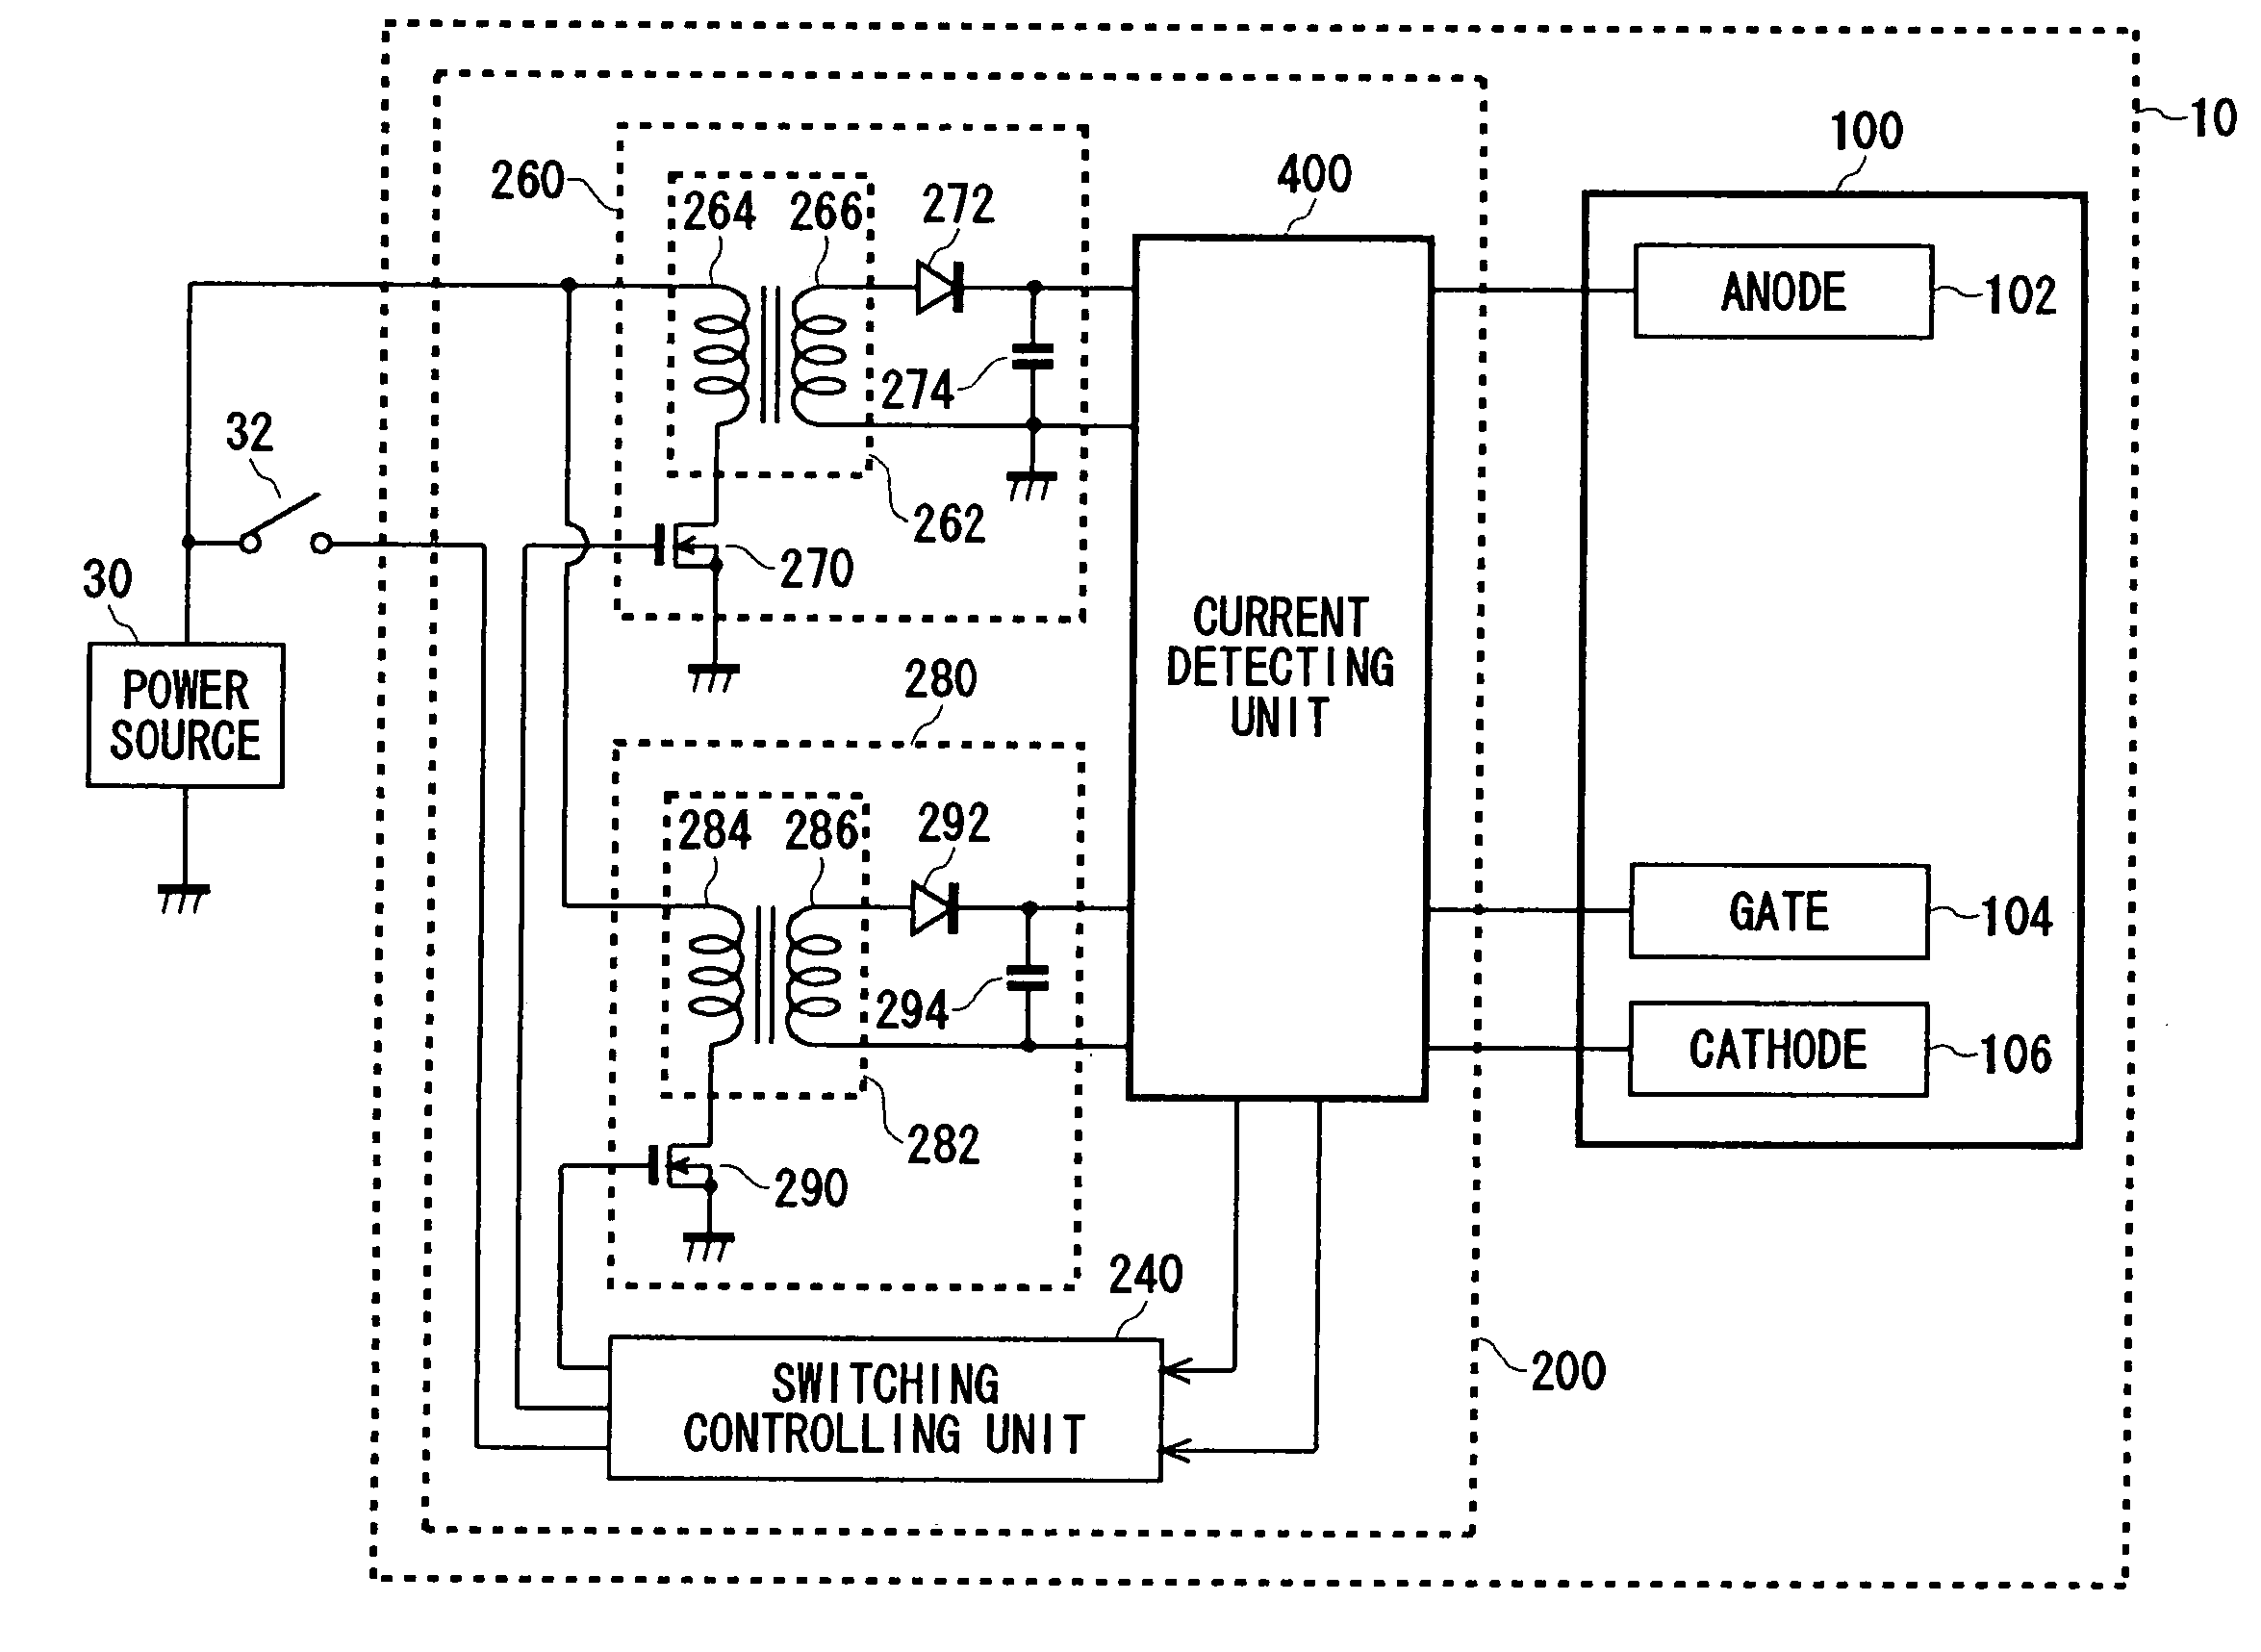
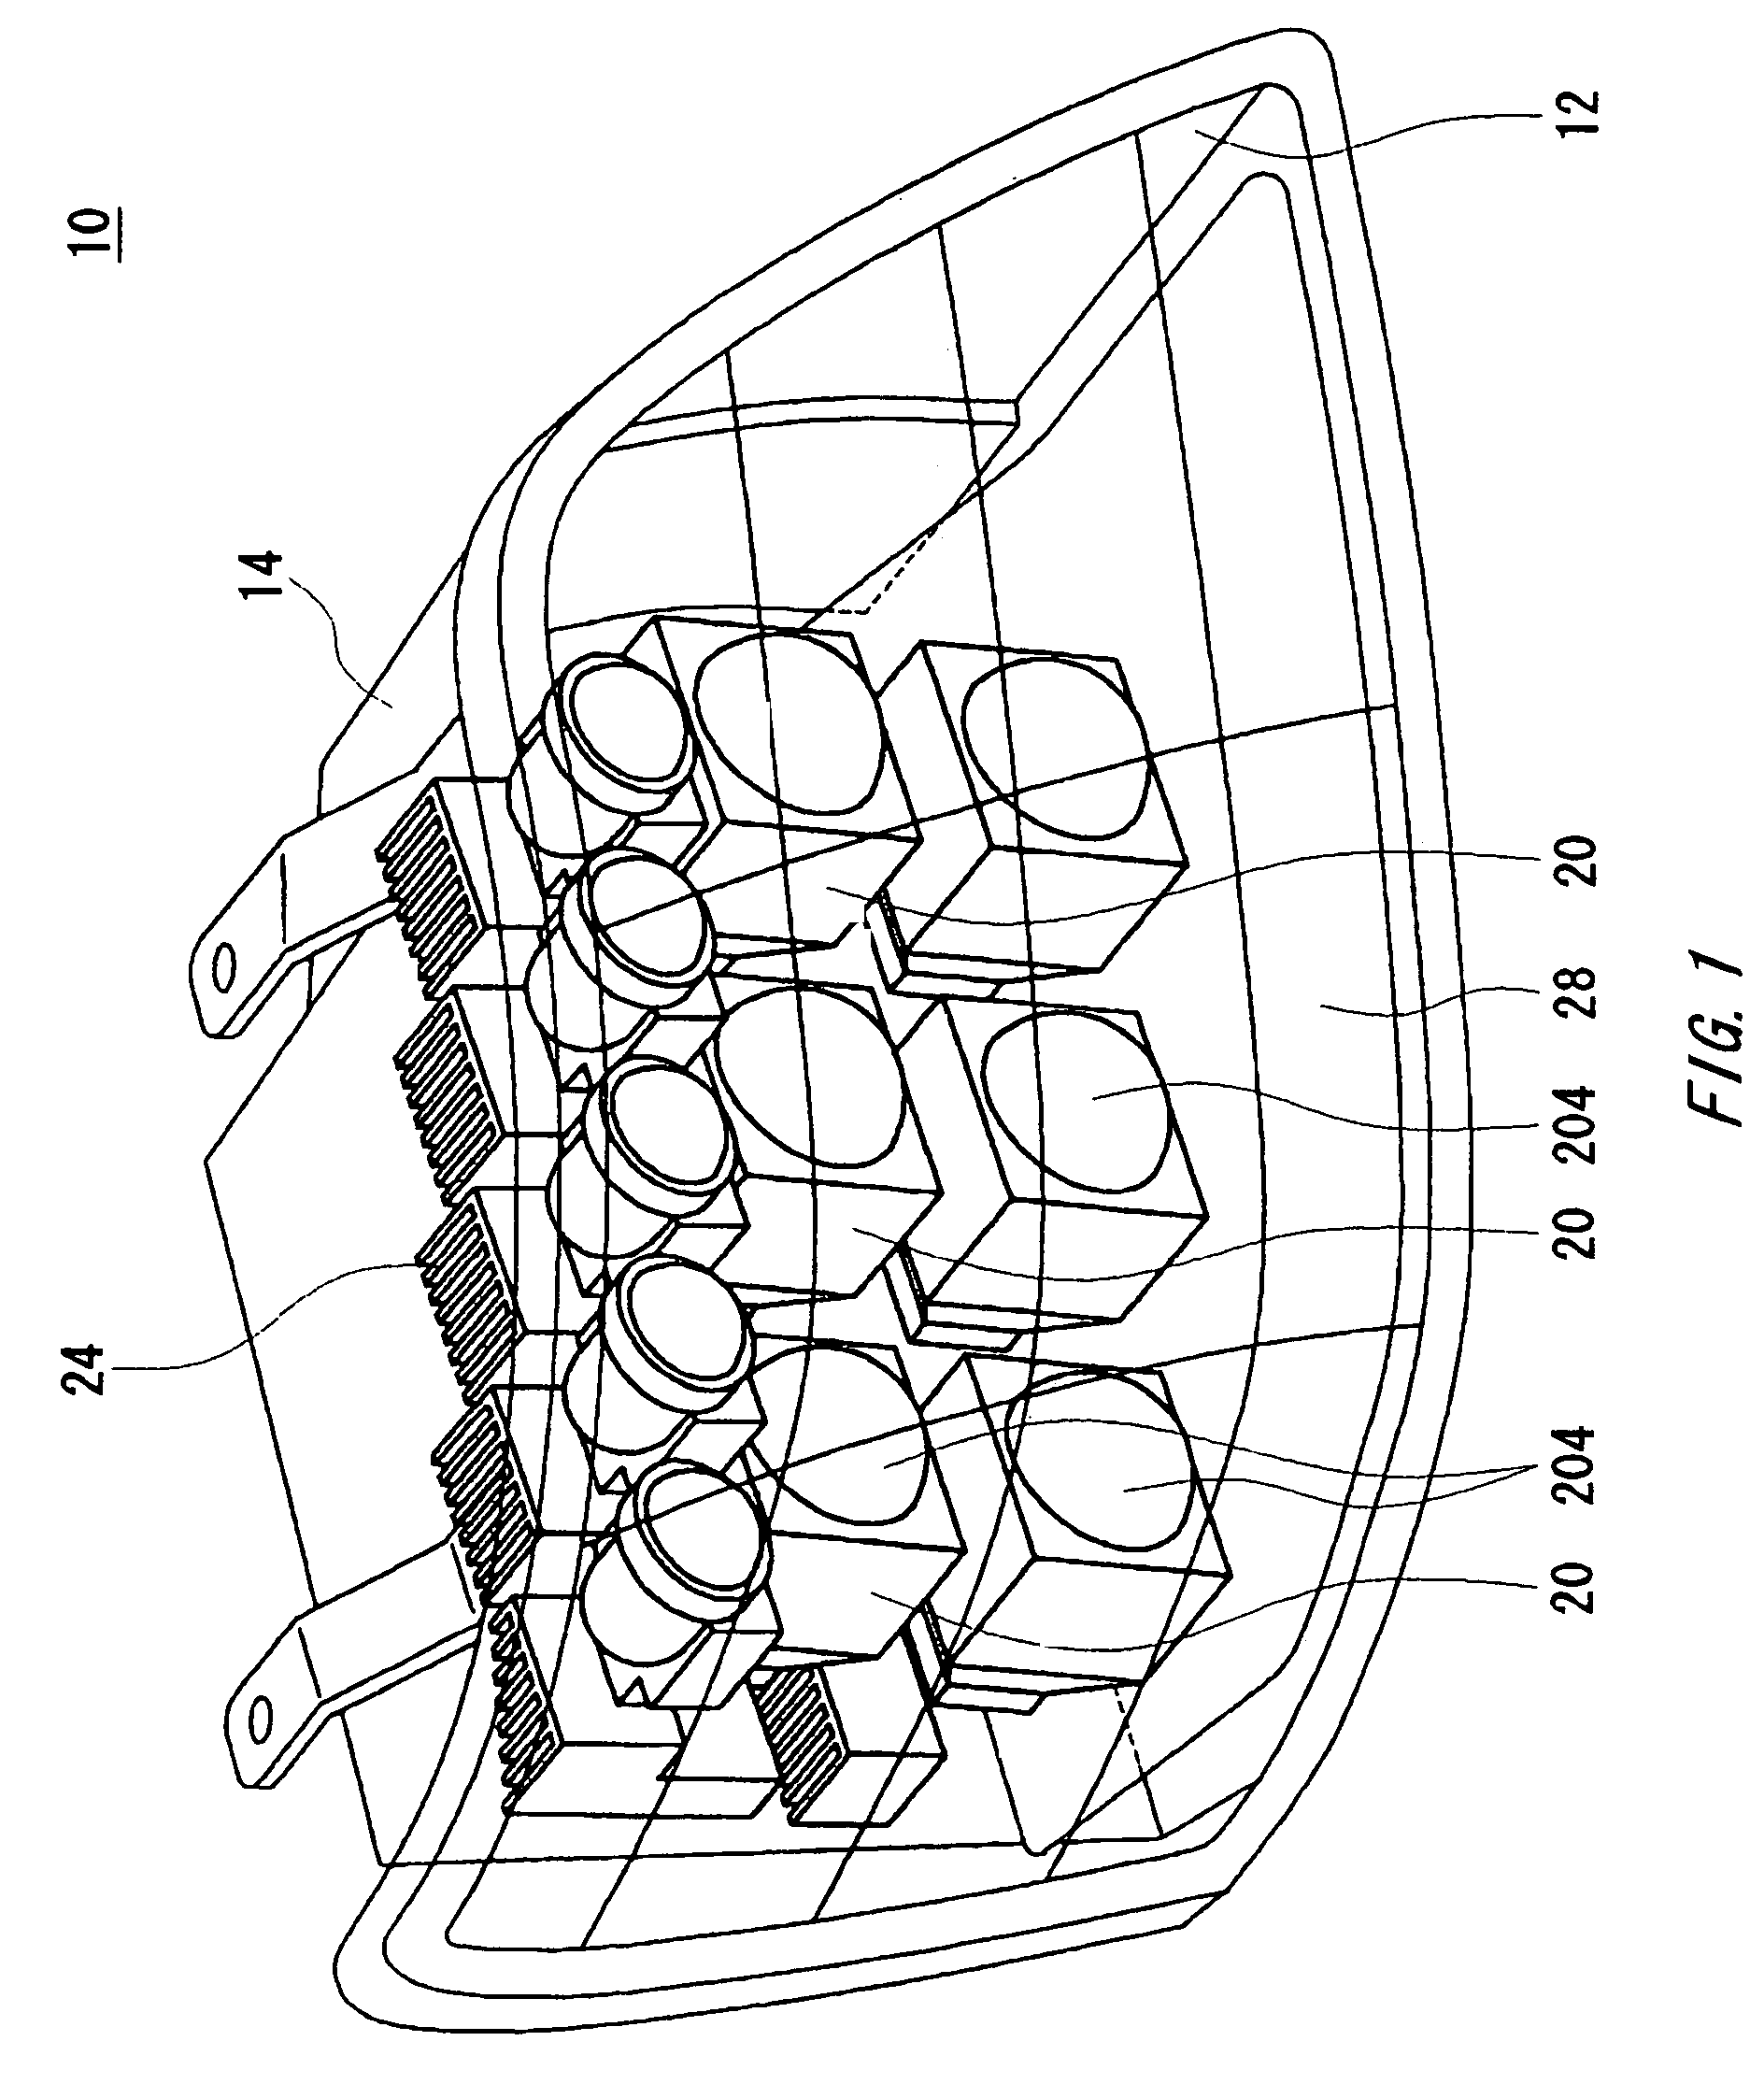
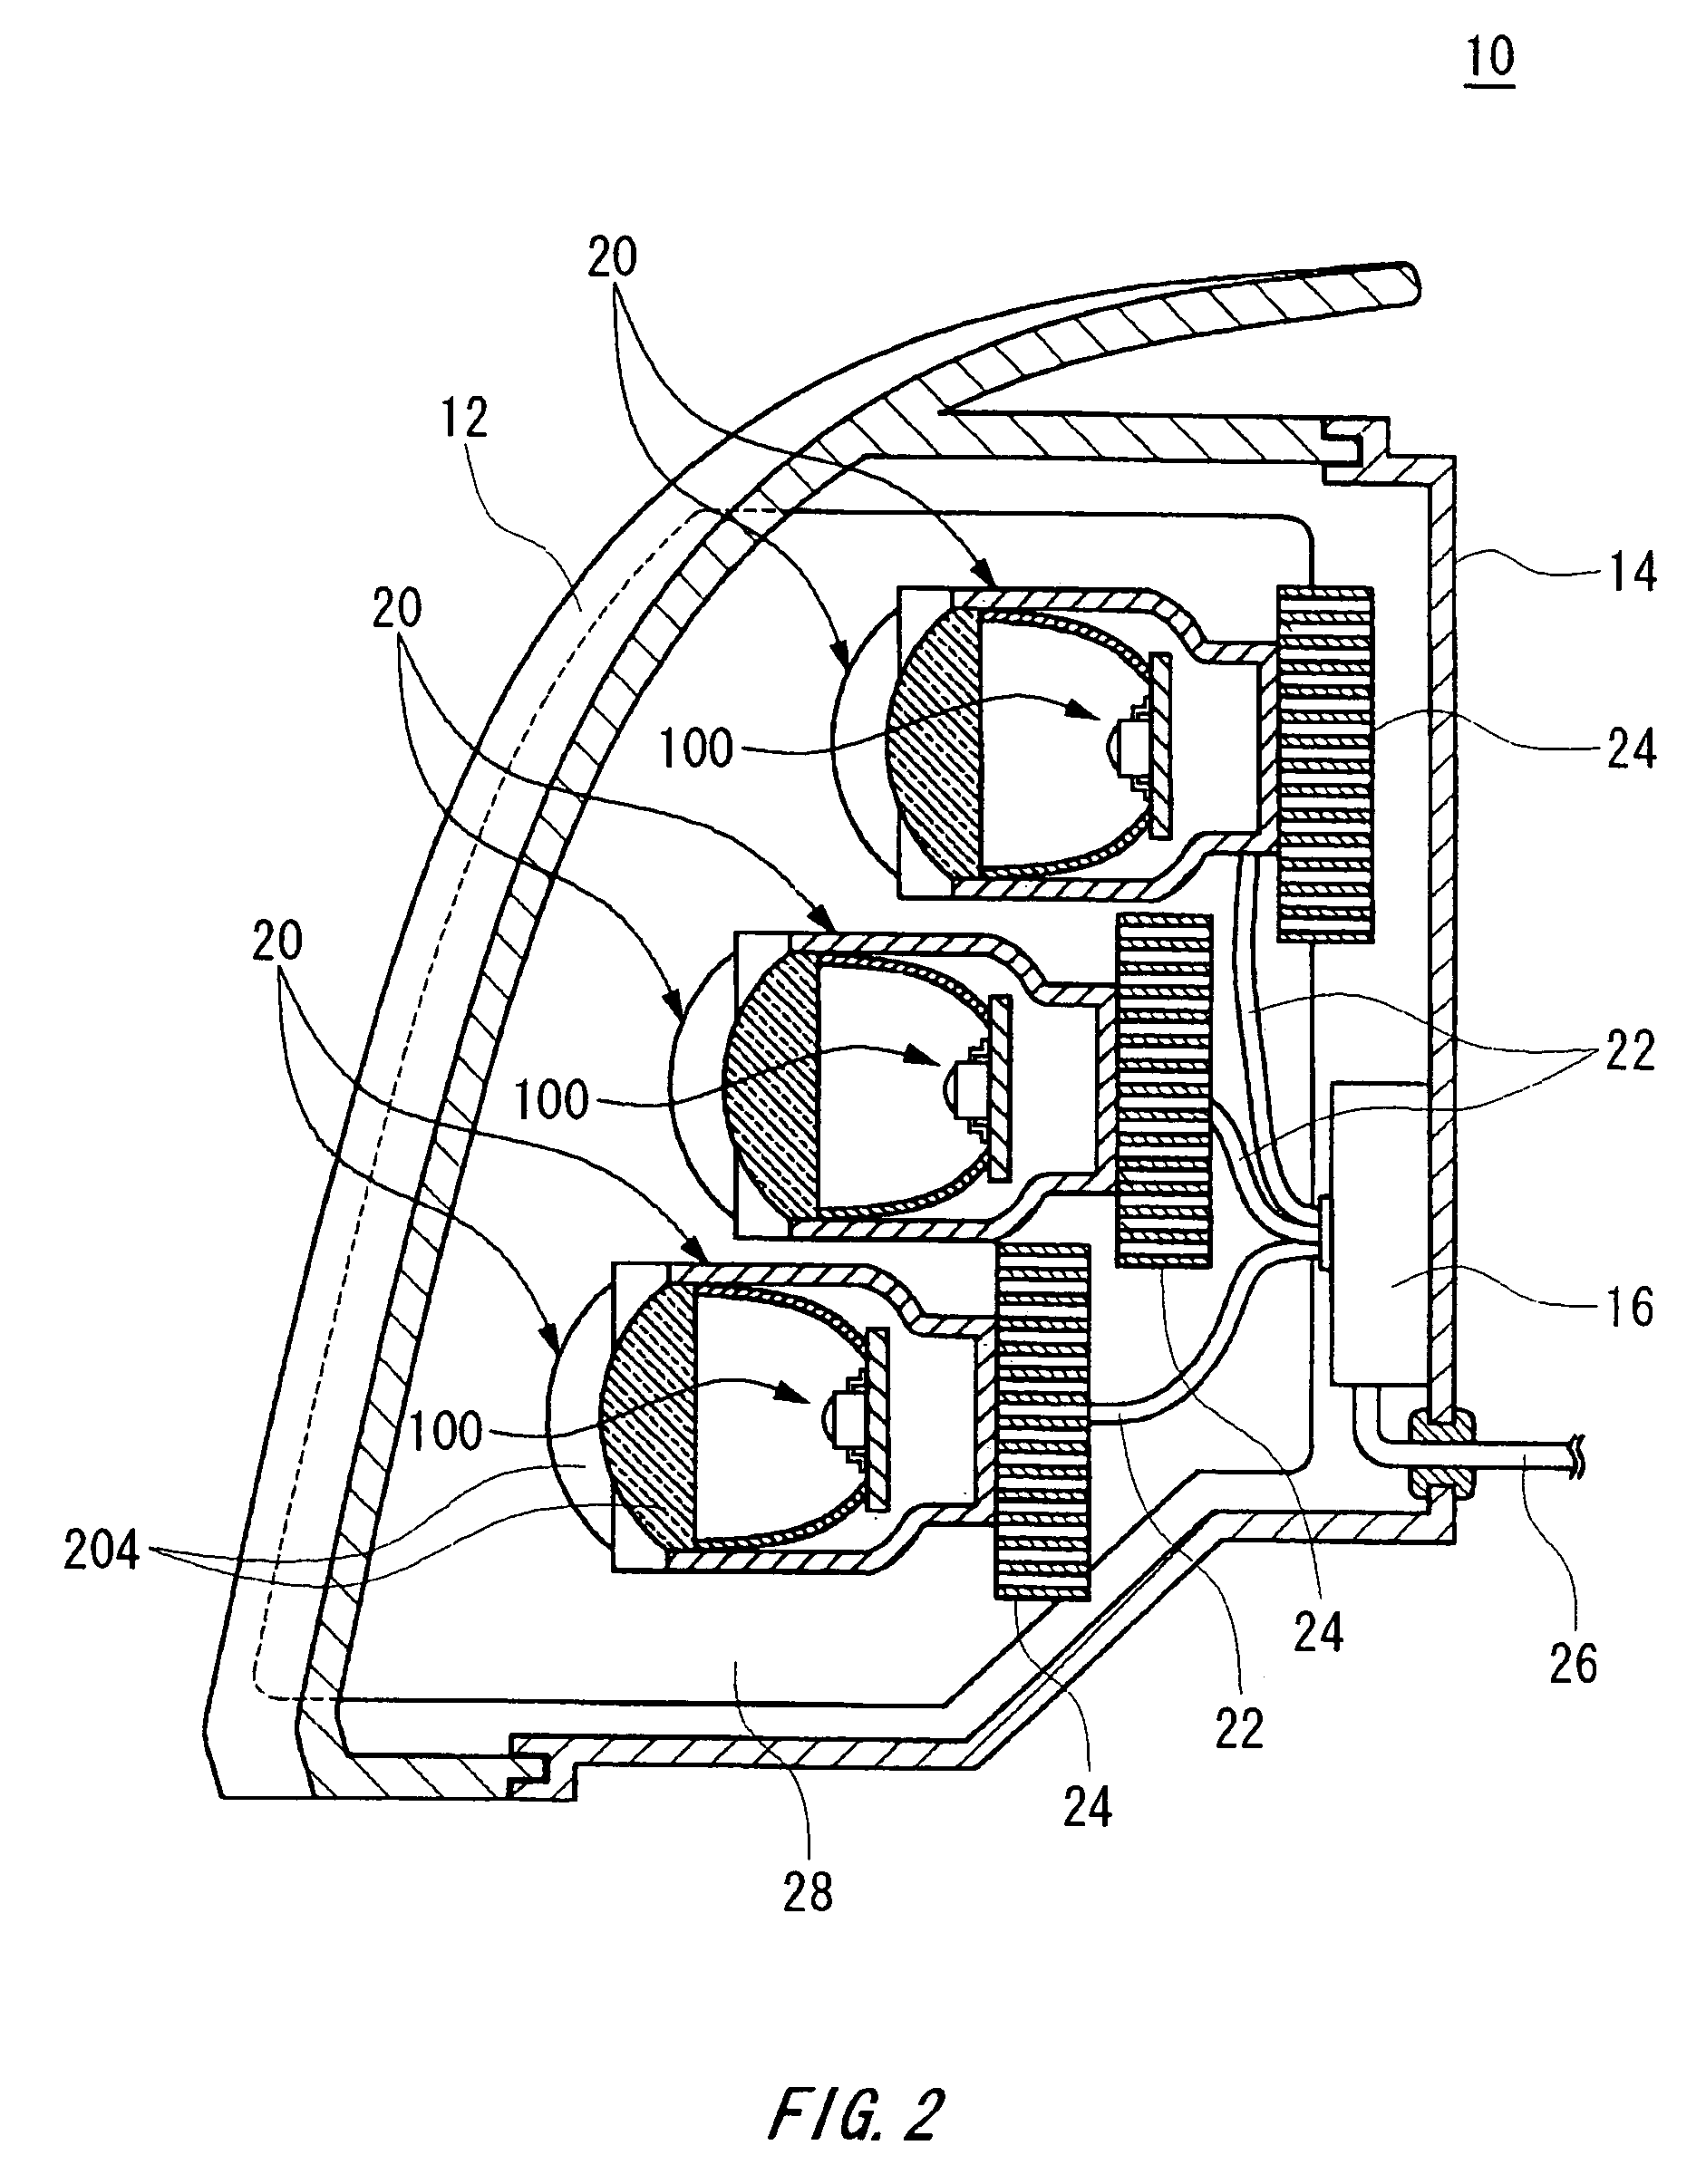
There is provided a vehicular lamp that can prevent excess current from flowing between an anode and a cathode at the lighting-up start to prevent a damage and life shortening of a cold cathode fluorescent lamp at low cost. The vehicular lamp includes: a cold cathode fluorescent lamp having a cathode, a gate, and an anode; and a lighting controlling unit operable to pre-discharge electricity from the cathode to the gate prior to lighting of the cold cathode fluorescent lamp, in which the lighting controlling unit applies a voltage between the cathode and the anode after once lowering a voltage between the cathode and the gate and then again applies an extraction voltage between the cathode and the gate in order to begin to discharge electricity from the cathode to the anode. The lighting controlling unit may pre-discharge electricity from the cathode to the gate until the temperature of the cathode is substantially equal to that of lighting-up time.
Owner:KOITO MFG CO LTD
Traffic signal lamp control device, system and method
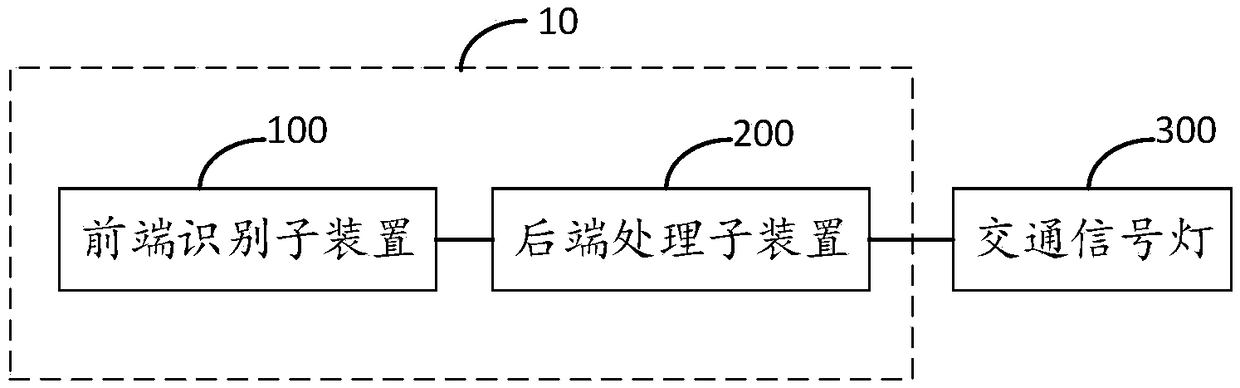
The invention relates to the technical field of intelligent traffic management, and provides a traffic signal lamp control device, system and method. The method comprises the steps that a front-end identification sub-device acquires multiple traffic images according to the preset time interval and analyzes each acquired traffic image so as to obtain the current traffic volume and transmit the current traffic volume to a rear-end processing sub-device; and the rear-end processing sub-device determines the light-up time of the traffic signal lamps according to the current traffic volume transmitted by the front-end identification sub-device and controls light-up of the traffic signal lamps according to the light-up time. The current traffic volume is detected in real time and the on / off timeof the traffic signal lamps is intelligently adjusted according to the current traffic volume so that the vehicles are enabled to pass according to the reasonable indication of the traffic signal lamps and the road congestion can be effectively reduced.
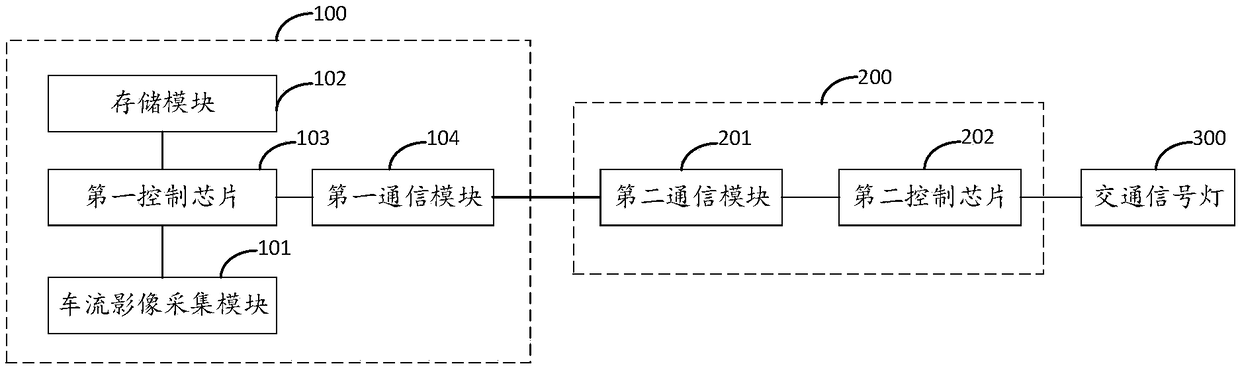
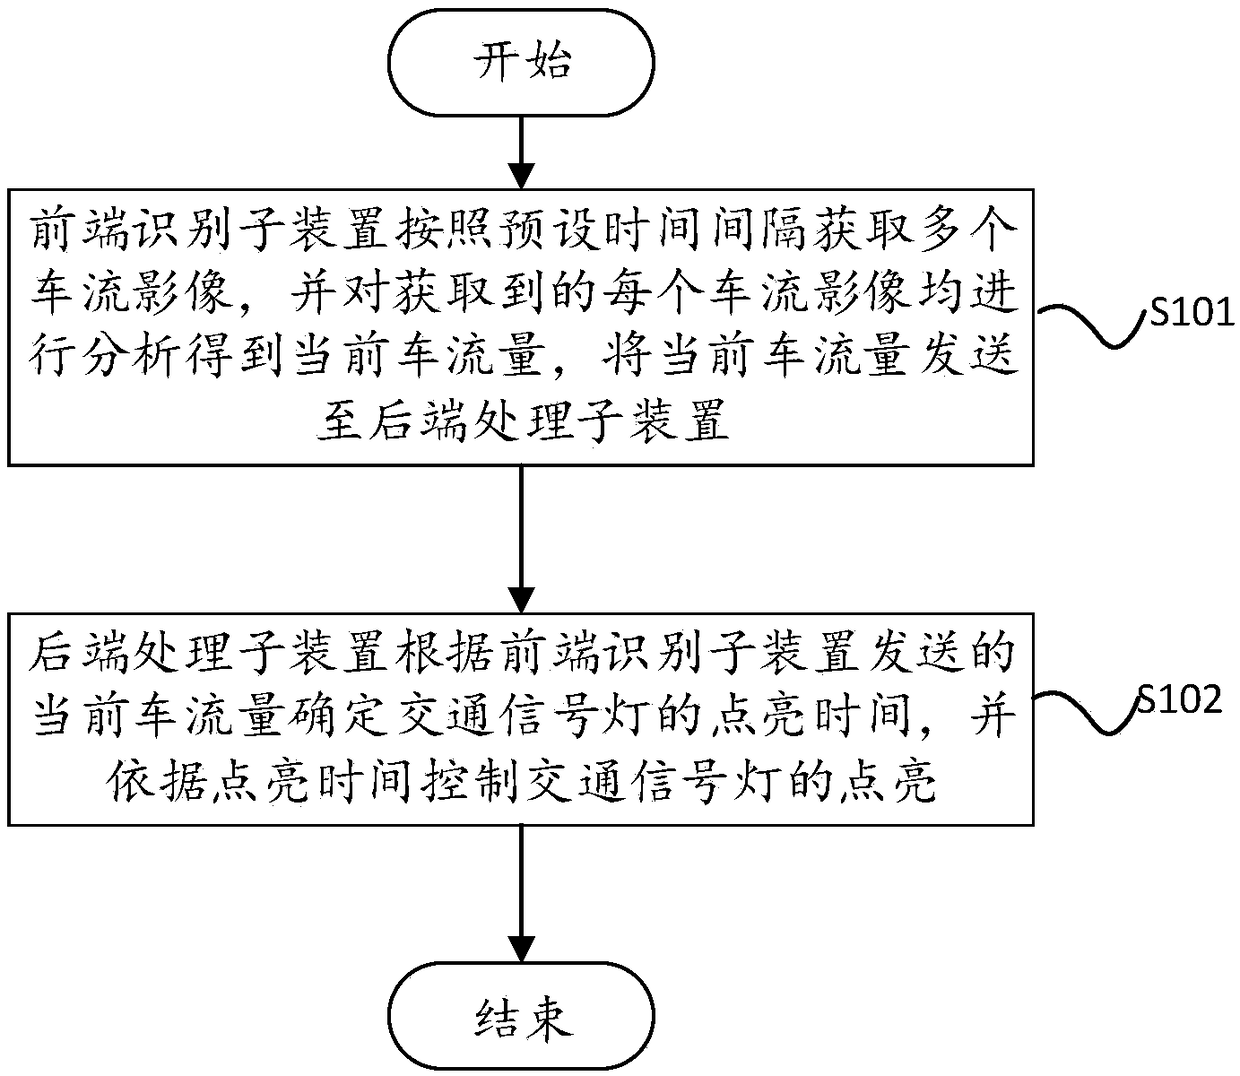
Owner:武汉市技领科技有限公司
Control method of traffic road cones and traffic road cones for implementing same
InactiveCN103882816AAuxiliary traffic managementElectric light circuit arrangementEnergy saving control techniquesLighting-up timeSimulation
A control method of traffic road cones includes 1, arranging N (N > / = 2) traffic road cones as one group of traffic guide devices; 2, determining the lighting time of the traffic road cones in each group of traffic guide devices to be t, sparkling intervals to be T, and sparkling periods of each group of traffic guide devices to be N*(t+T), and allowing a first device to be lighted once more via T after a last device extinguishes; 3, powering on the N traffic road cones according to the intervals t+T sequentially, and allowing the lighting time of each traffic road cone to be t and the intervals between extinguishing and lighting of two adjacent devices to be T; in the group of traffic guide devices, allowing the traffic road cones to sparkle sequentially to form orientated sparkling patterns to perform traffic guide indication. According to the control method of the traffic road cones, a plurality of devices in a same classification are utilized simultaneously in a combined manner to form lighting combinations with certain sparkling rules and recognizing significances, accordingly special traffic information is released, and the method is used for assisting traffic management.
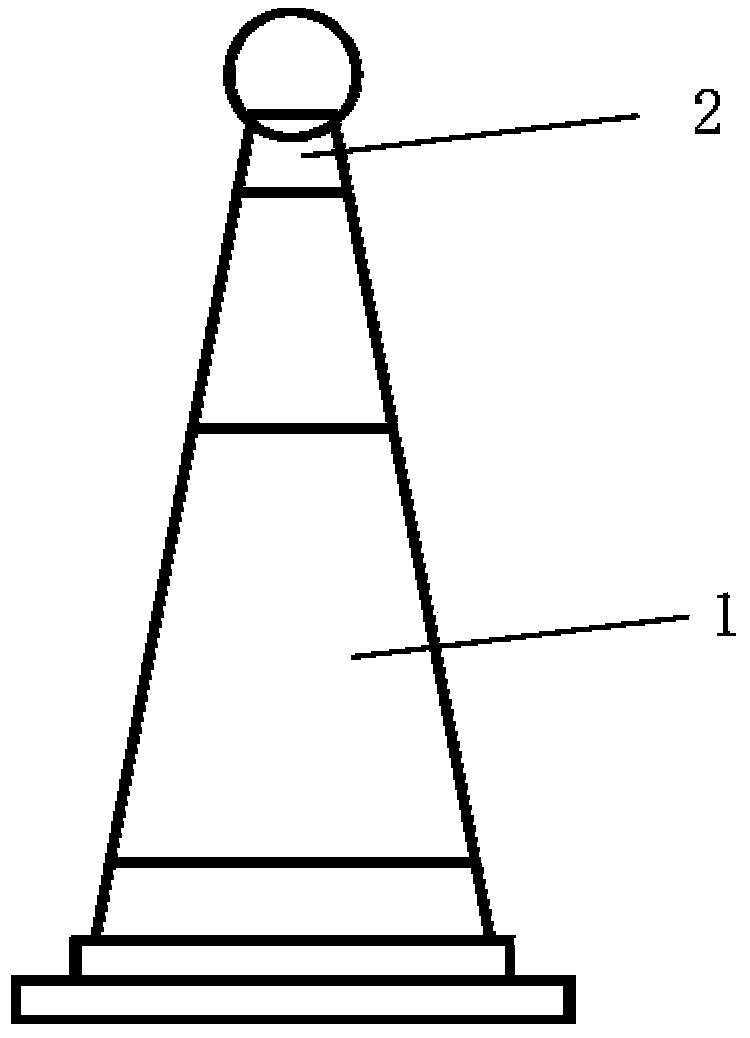
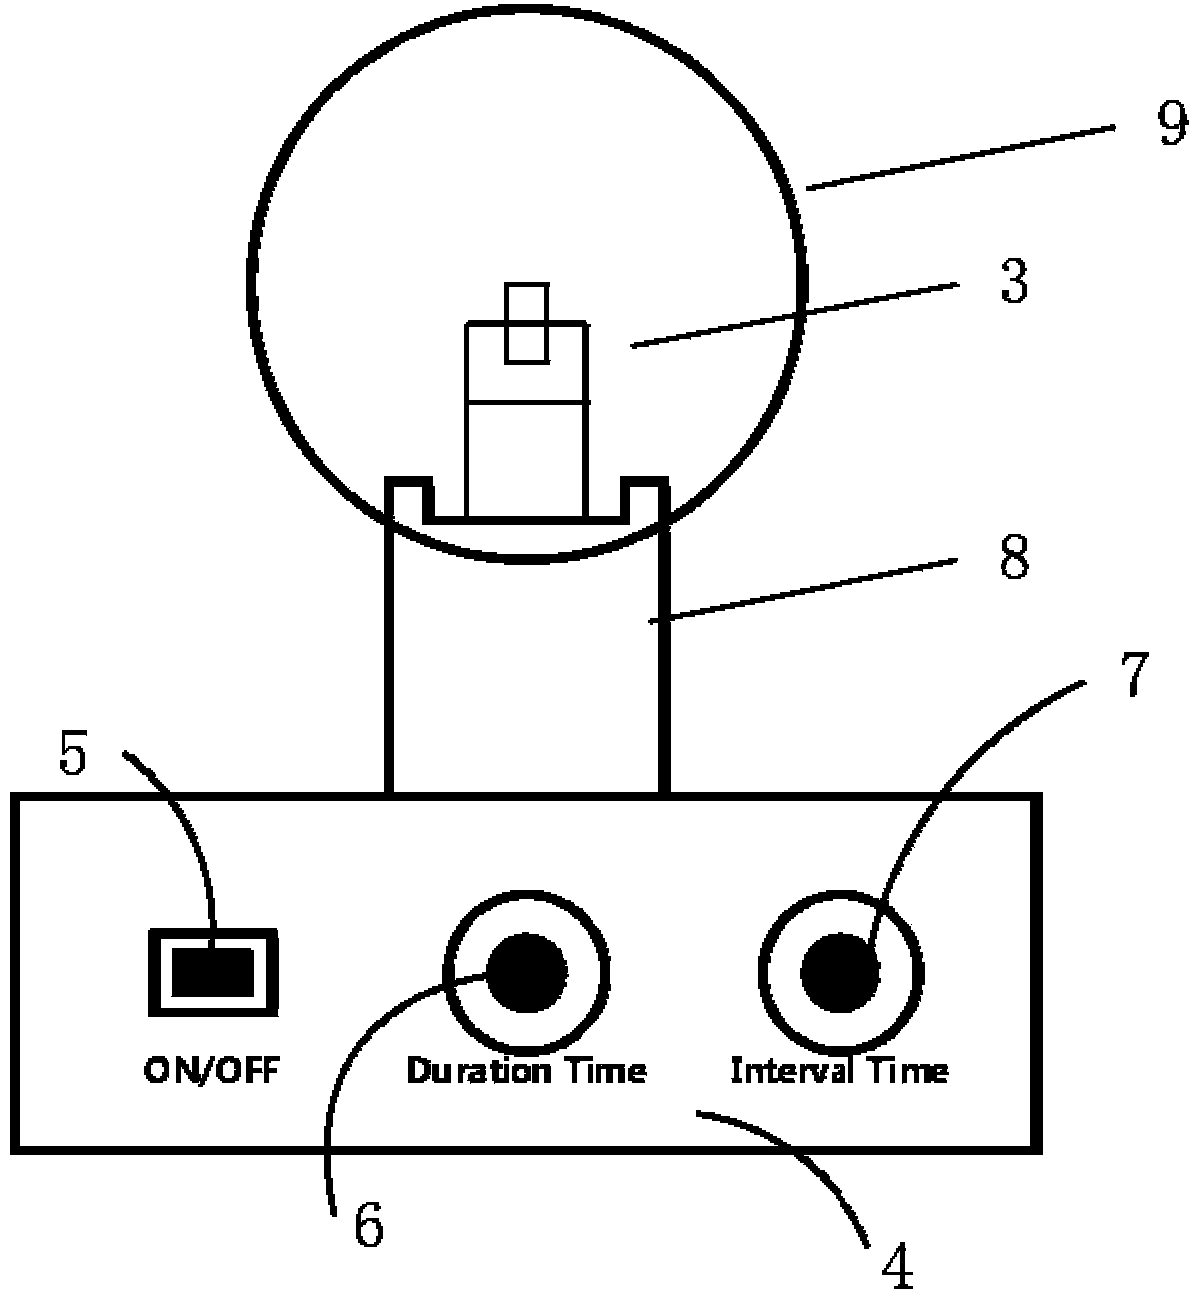
Owner:TONGJI UNIV
Ignition method of W-shaped boiler
ActiveCN106016356AFast ignitionShorten ignition timePilot flame ignitersLump/pulverulent fuel feeder/distributionLighting-up timeFuel oil
The invention discloses an ignition method of a W-shaped boiler, relates to an ignition method of a boiler, and particularly relates to the ignition method of the W-shaped boiler. The ignition method of the W-shaped boiler comprises a cold-start ignition method and a hot-start ignition method of the boiler, wherein the cold start of the boiler is the ignition for start after the boiler stops running for not less than 48 hours; and the hot start of the boiler is the ignition for the start after the boiler stops running for less than 8 hours but not less than 2 hours. According to the ignition method of the W-shaped boiler, which is provided by the invention, on one hand, the ignition is carried out by utilizing the characteristic that soft coal is inflammable; on the other hand, coal mills are started orderly according to a sequence; coal powder is slowly added into the boiler amount by amount; the quick ignition of the boiler is realized; the lighting-up time of the coal powder in the boiler and the start time of a whole unit are shortened; meanwhile, an oil gun can be withdrawn when the load of the unit reaches 35 percent; the consumption of fuel oil is decreased; and the production cost is saved to a great extent.
Owner:NORTHWEST BRANCH OF CHINA DATANG CORP SCI & TECH RES INST
Sound-light control circuit and lamp
InactiveCN104427706ASave energyReduce the hassle of manual operationElectric light circuit arrangementLighting-up timeControl cell
Owner:OCEANKING DONGGUAN LIGHTING TECH +2
Time-sharing stroboscopic controller control system and control method thereof
PendingCN119629806ASolve the problem of detection inaccuracyReal-time monitoring and dynamic adjustment of trigger signal errorsElectrical apparatusEnergy saving control techniquesControl signalControl system
The invention relates to the technical field of stroboscopic controllers, and discloses a time-sharing stroboscopic controller control system, which comprises a stroboscopic controller module used for receiving an external trigger signal, generating a multi-time-sequence light source control signal according to the signal, and controlling the lightening time, the extinguishing time, the lightening sequence and the brightness of a light source module; the invention also discloses a control method of the time-sharing stroboscopic controller, which comprises the following steps of: S1, receiving an external trigger signal through the stroboscopic controller module, and starting a light source lightening process; and S2, the stroboscopic controller module generates a lighting time sequence control signal of the light source module according to the external trigger signal. Through a high-precision time synchronization technology, a closed-loop calibration mechanism and a multi-time-sequence multi-channel control design, the problems of inaccurate synchronization of multi-device trigger signals, error accumulation and inflexible cooperative operation of a light source and a camera are solved, and the adaptive capacity and the system reliability in a complex detection scene are remarkably improved.

Owner:SUZHOU JIALI AUTOMATION TECH CO LTD
Power-Saving Lighting Apparatus
InactiveUS20150245452A1Save powerElectrical apparatusElectroluminescent light sourcesLighting-up timeTime segment
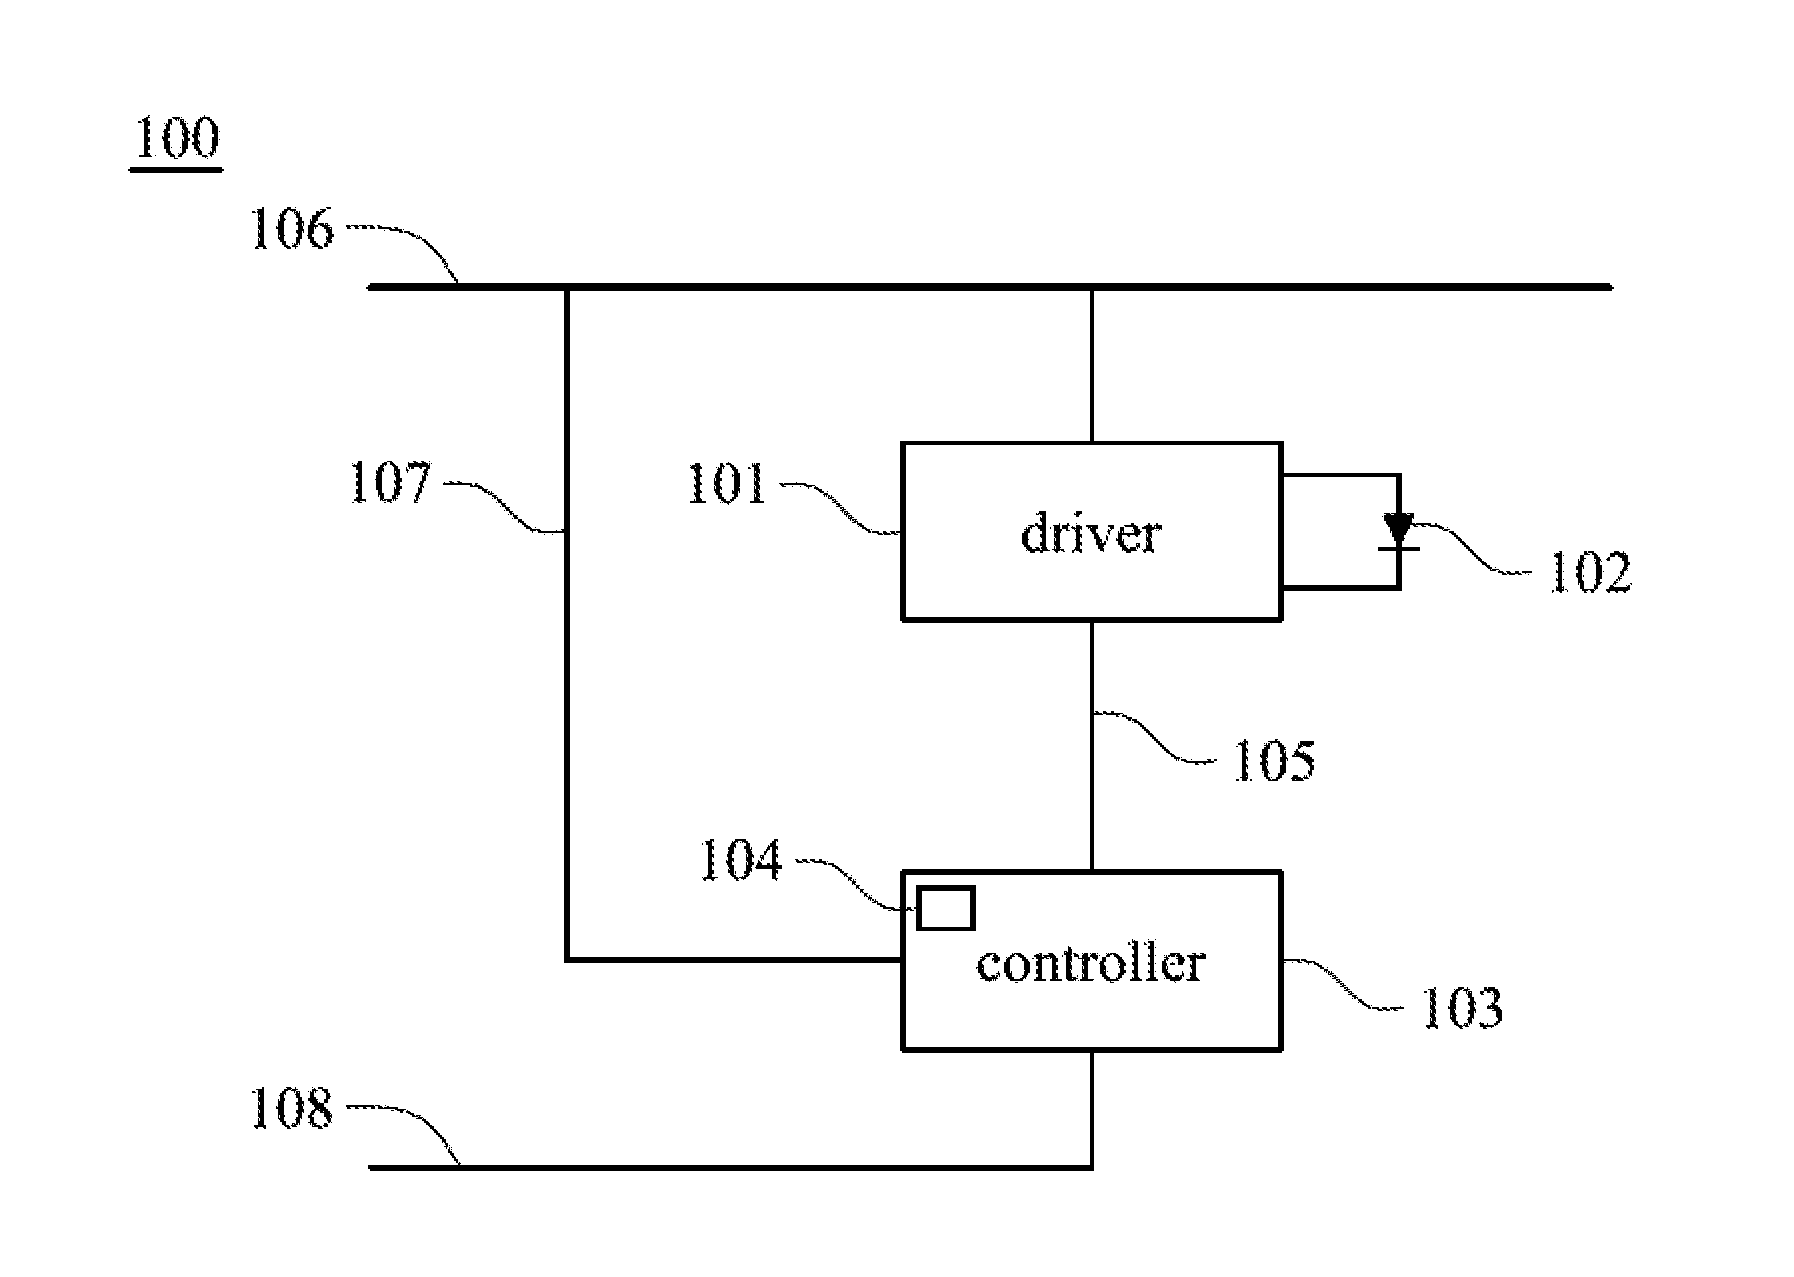
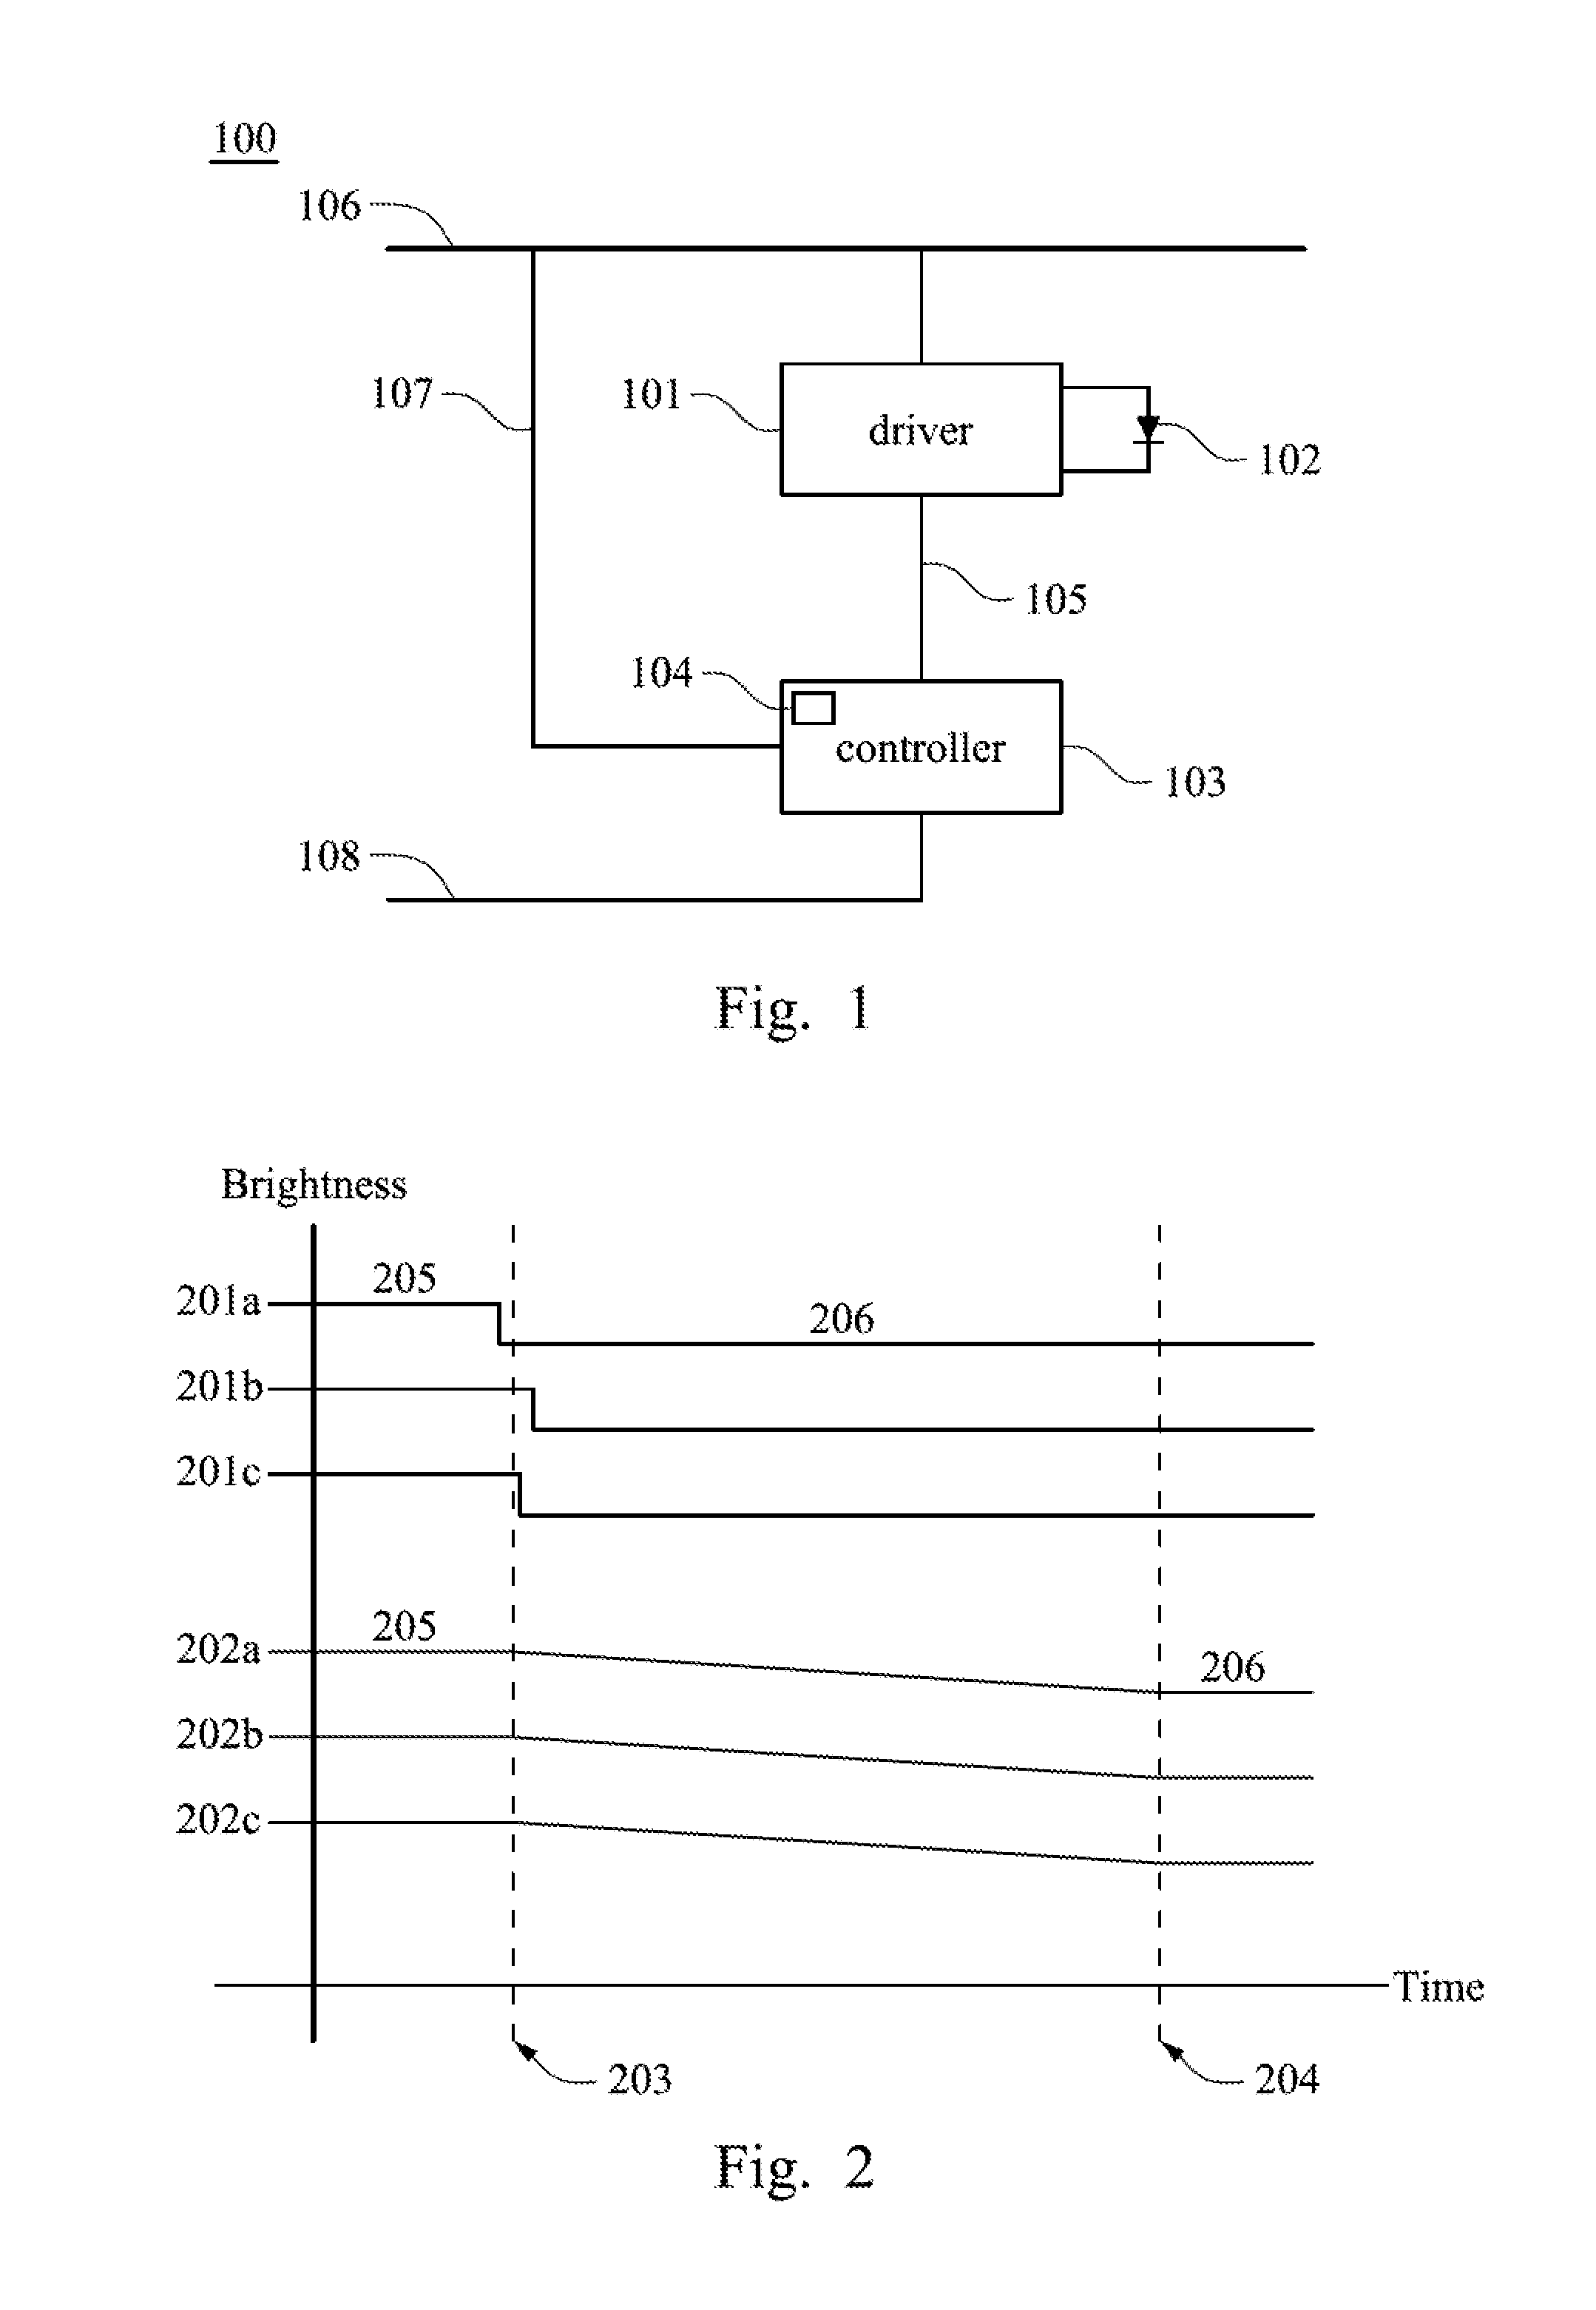
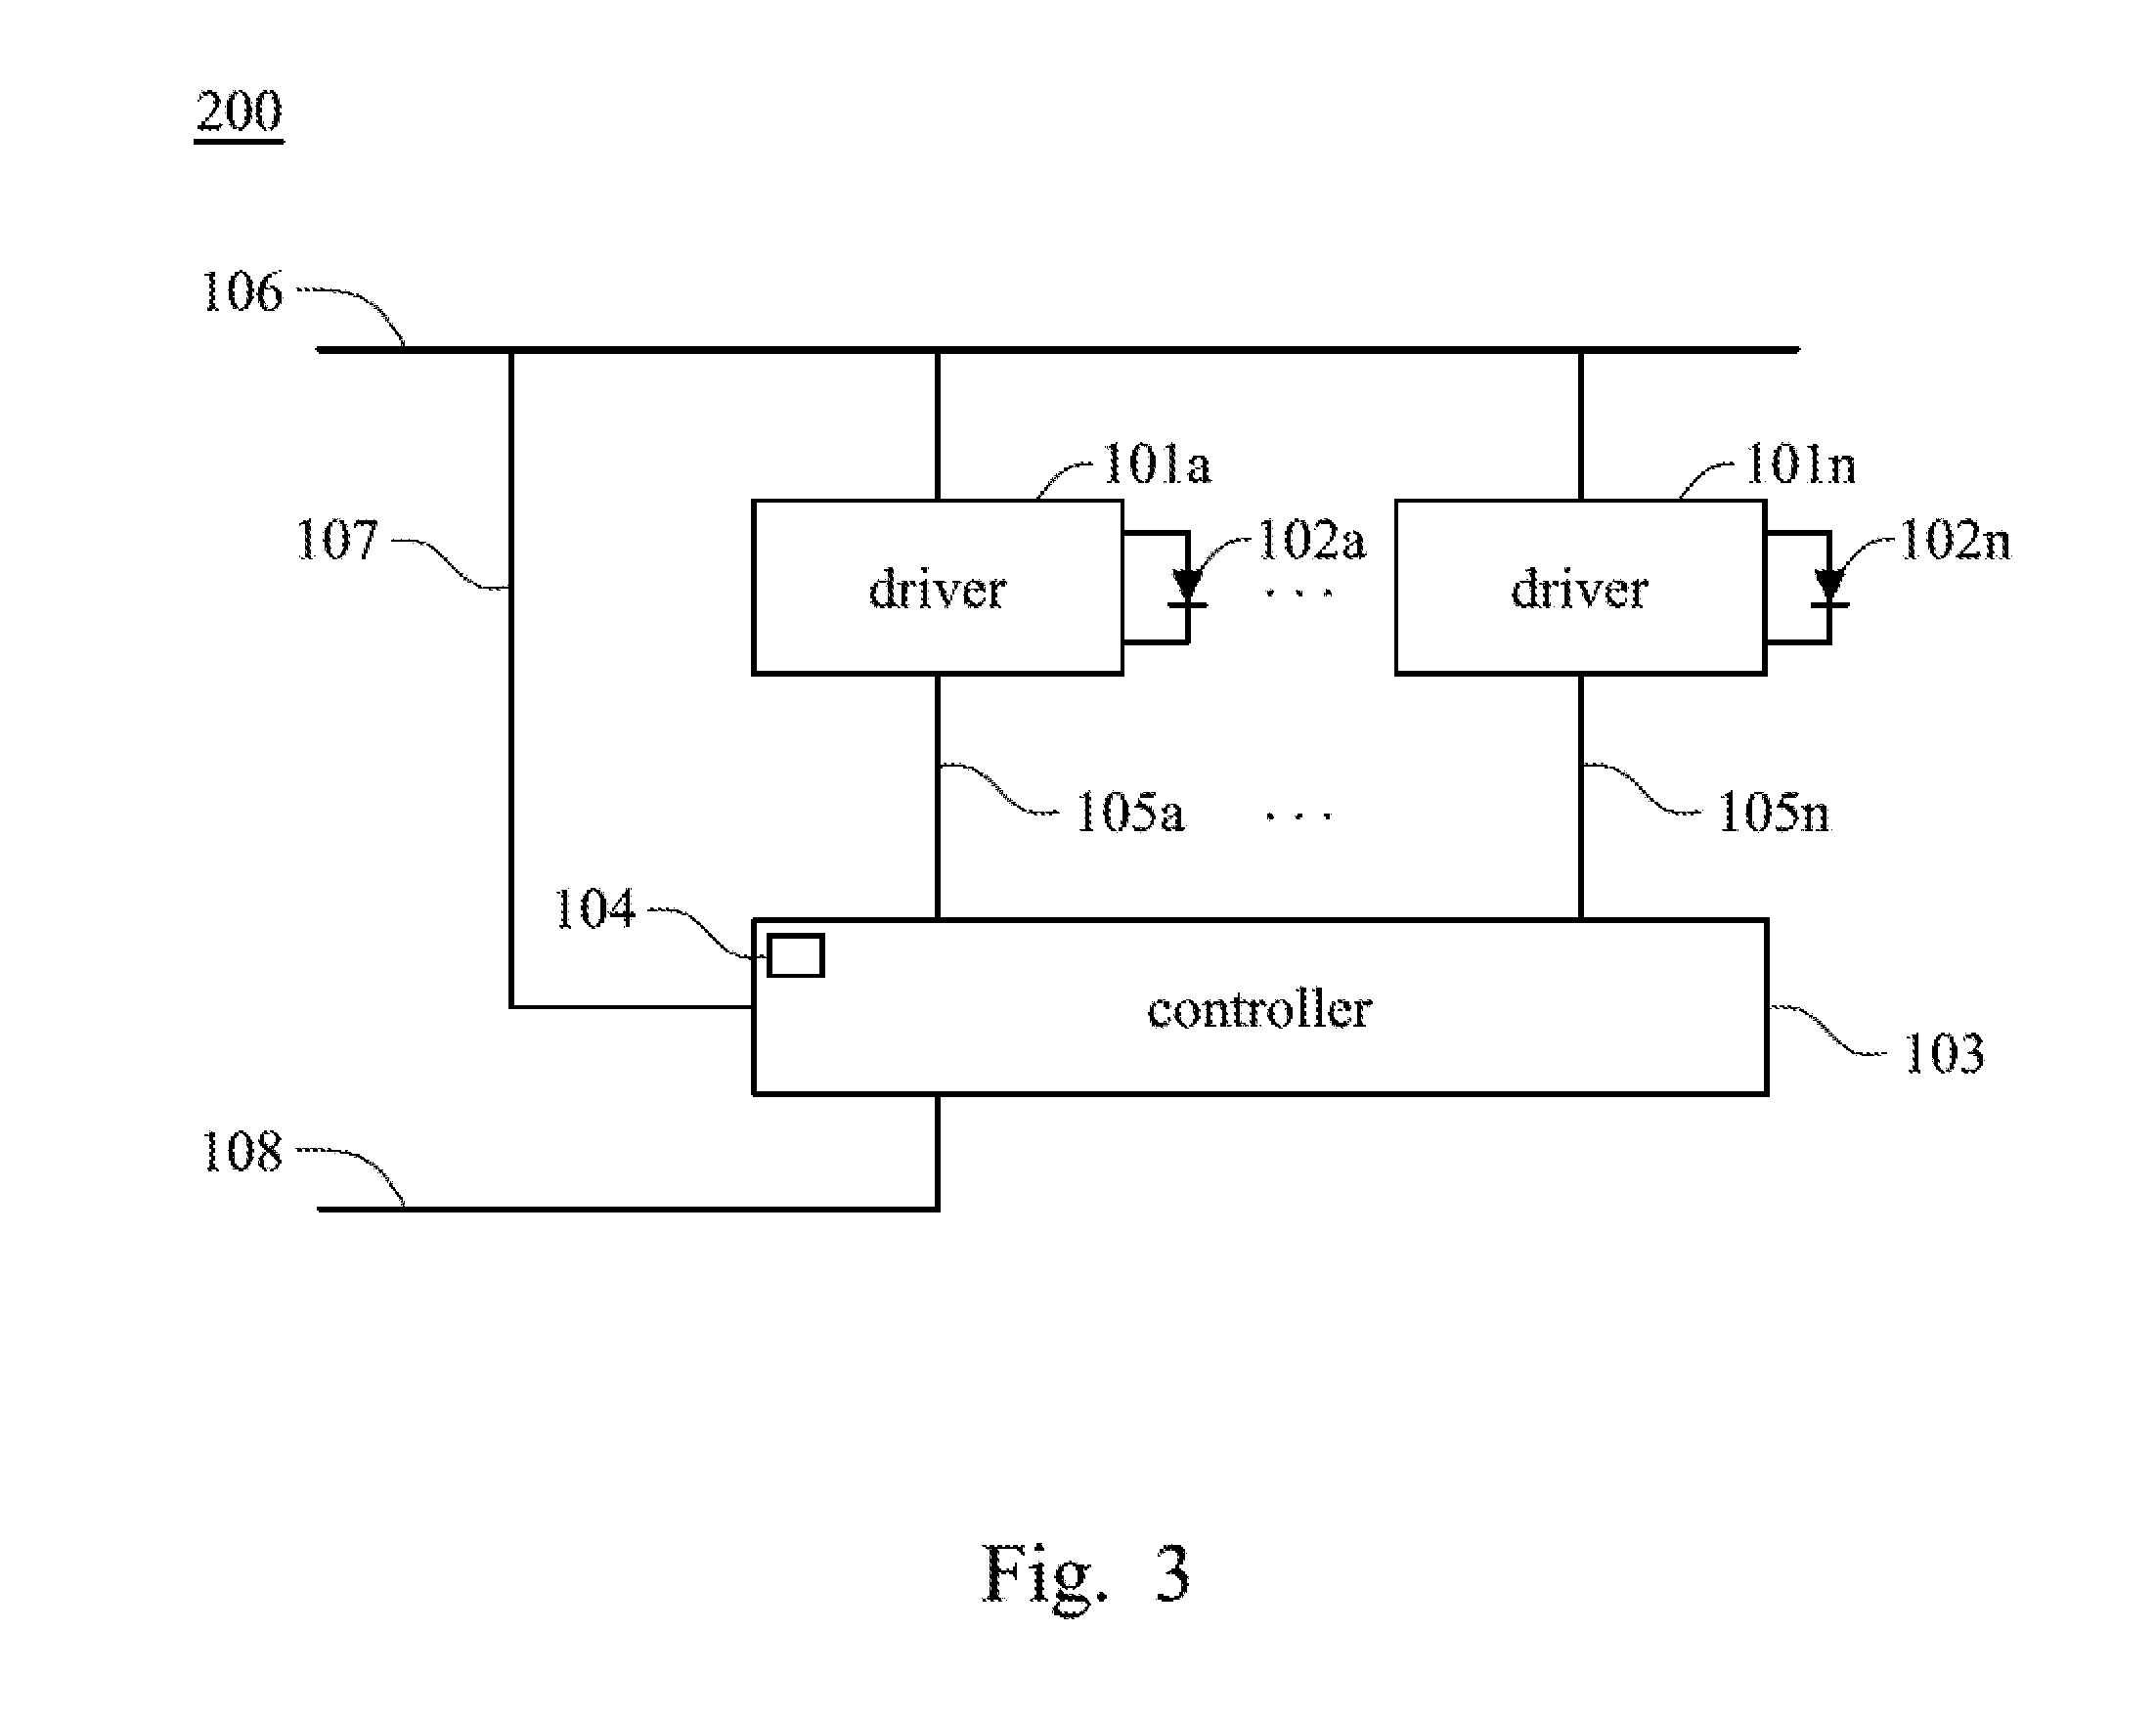
A power-saving lighting apparatus is provided, and includes at least one light source, at least one driver, a controller and a memory. The driver is coupled with the light source. The controller is coupled with the driver. The memory with a time table is coupled with the controller. The time table records lighting-up time periods and their corresponding brightness data of the light source. The controller controls the light source according to the lighting-up time periods and their corresponding brightness data.
Owner:STAR REACH
3D camera galvanometer module motion nonlinear error calibration method and system
The invention relates to a 3D camera galvanometer module motion nonlinear error calibration method, and the method comprises the steps: determining a target galvanometer delay parameter enabling the center position of the reciprocating motion of a galvanometer motor to be aligned under the preset initial camera exposure time and initial galvanometer motion time, and adjusting the stepping modification camera exposure time and galvanometer motion time, the corresponding relation between camera exposure time and galvanometer delay parameters is obtained, the lightening time of the laser at different positions is determined with the minimum nonlinear error of reciprocating motion of the galvanometer motor as the target under different camera exposure time and galvanometer motion time, and the laser is controlled according to the lightening time. And laser compensation parameters when the galvanometer motor operates to different positions at different galvanometer movement speeds are obtained. According to the application, the problem of inaccurate imaging caused by nonlinear errors existing in positive and negative motion of galvanometer structured light projection in related technologies is solved, and the nonlinear errors existing in the positive and negative motion are eliminated through the galvanometer delay parameter and the laser compensation parameter.

Owner:HANGZHOU LINGXI ROBOT INTELLIGENT TECH CO LTD
Vehicular lamp, cold cathode fluorescent lamp lighting apparatus, and cold cathode fluorescent lamp lighting method
InactiveUS7157864B2Convenient lightingAvoid damageElectrical apparatusElectric light circuit arrangementElectricityLighting-up time
There is provided a vehicular lamp that can prevent excess current from flowing between an anode and a cathode at the lighting-up start to prevent a damage and life shortening of a cold cathode fluorescent lamp at low cost. The vehicular lamp includes: a cold cathode fluorescent lamp having a cathode, a gate, and an anode; and a lighting controlling unit operable to pre-discharge electricity from the cathode to the gate prior to lighting of the cold cathode fluorescent lamp, in which the lighting controlling unit applies a voltage between the cathode and the anode after once lowering a voltage between the cathode and the gate and then again applies an extraction voltage between the cathode and the gate in order to begin to discharge electricity from the cathode to the anode. The lighting controlling unit may pre-discharge electricity from the cathode to the gate until the temperature of the cathode is substantially equal to that of lighting-up time.
Owner:KOITO MFG CO LTD
Electro-optical apparatus, driving method thereof, and electronic device
InactiveUS7394442B2Electroluminescent light sourcesSolid-state devicesDriving currentLighting-up time
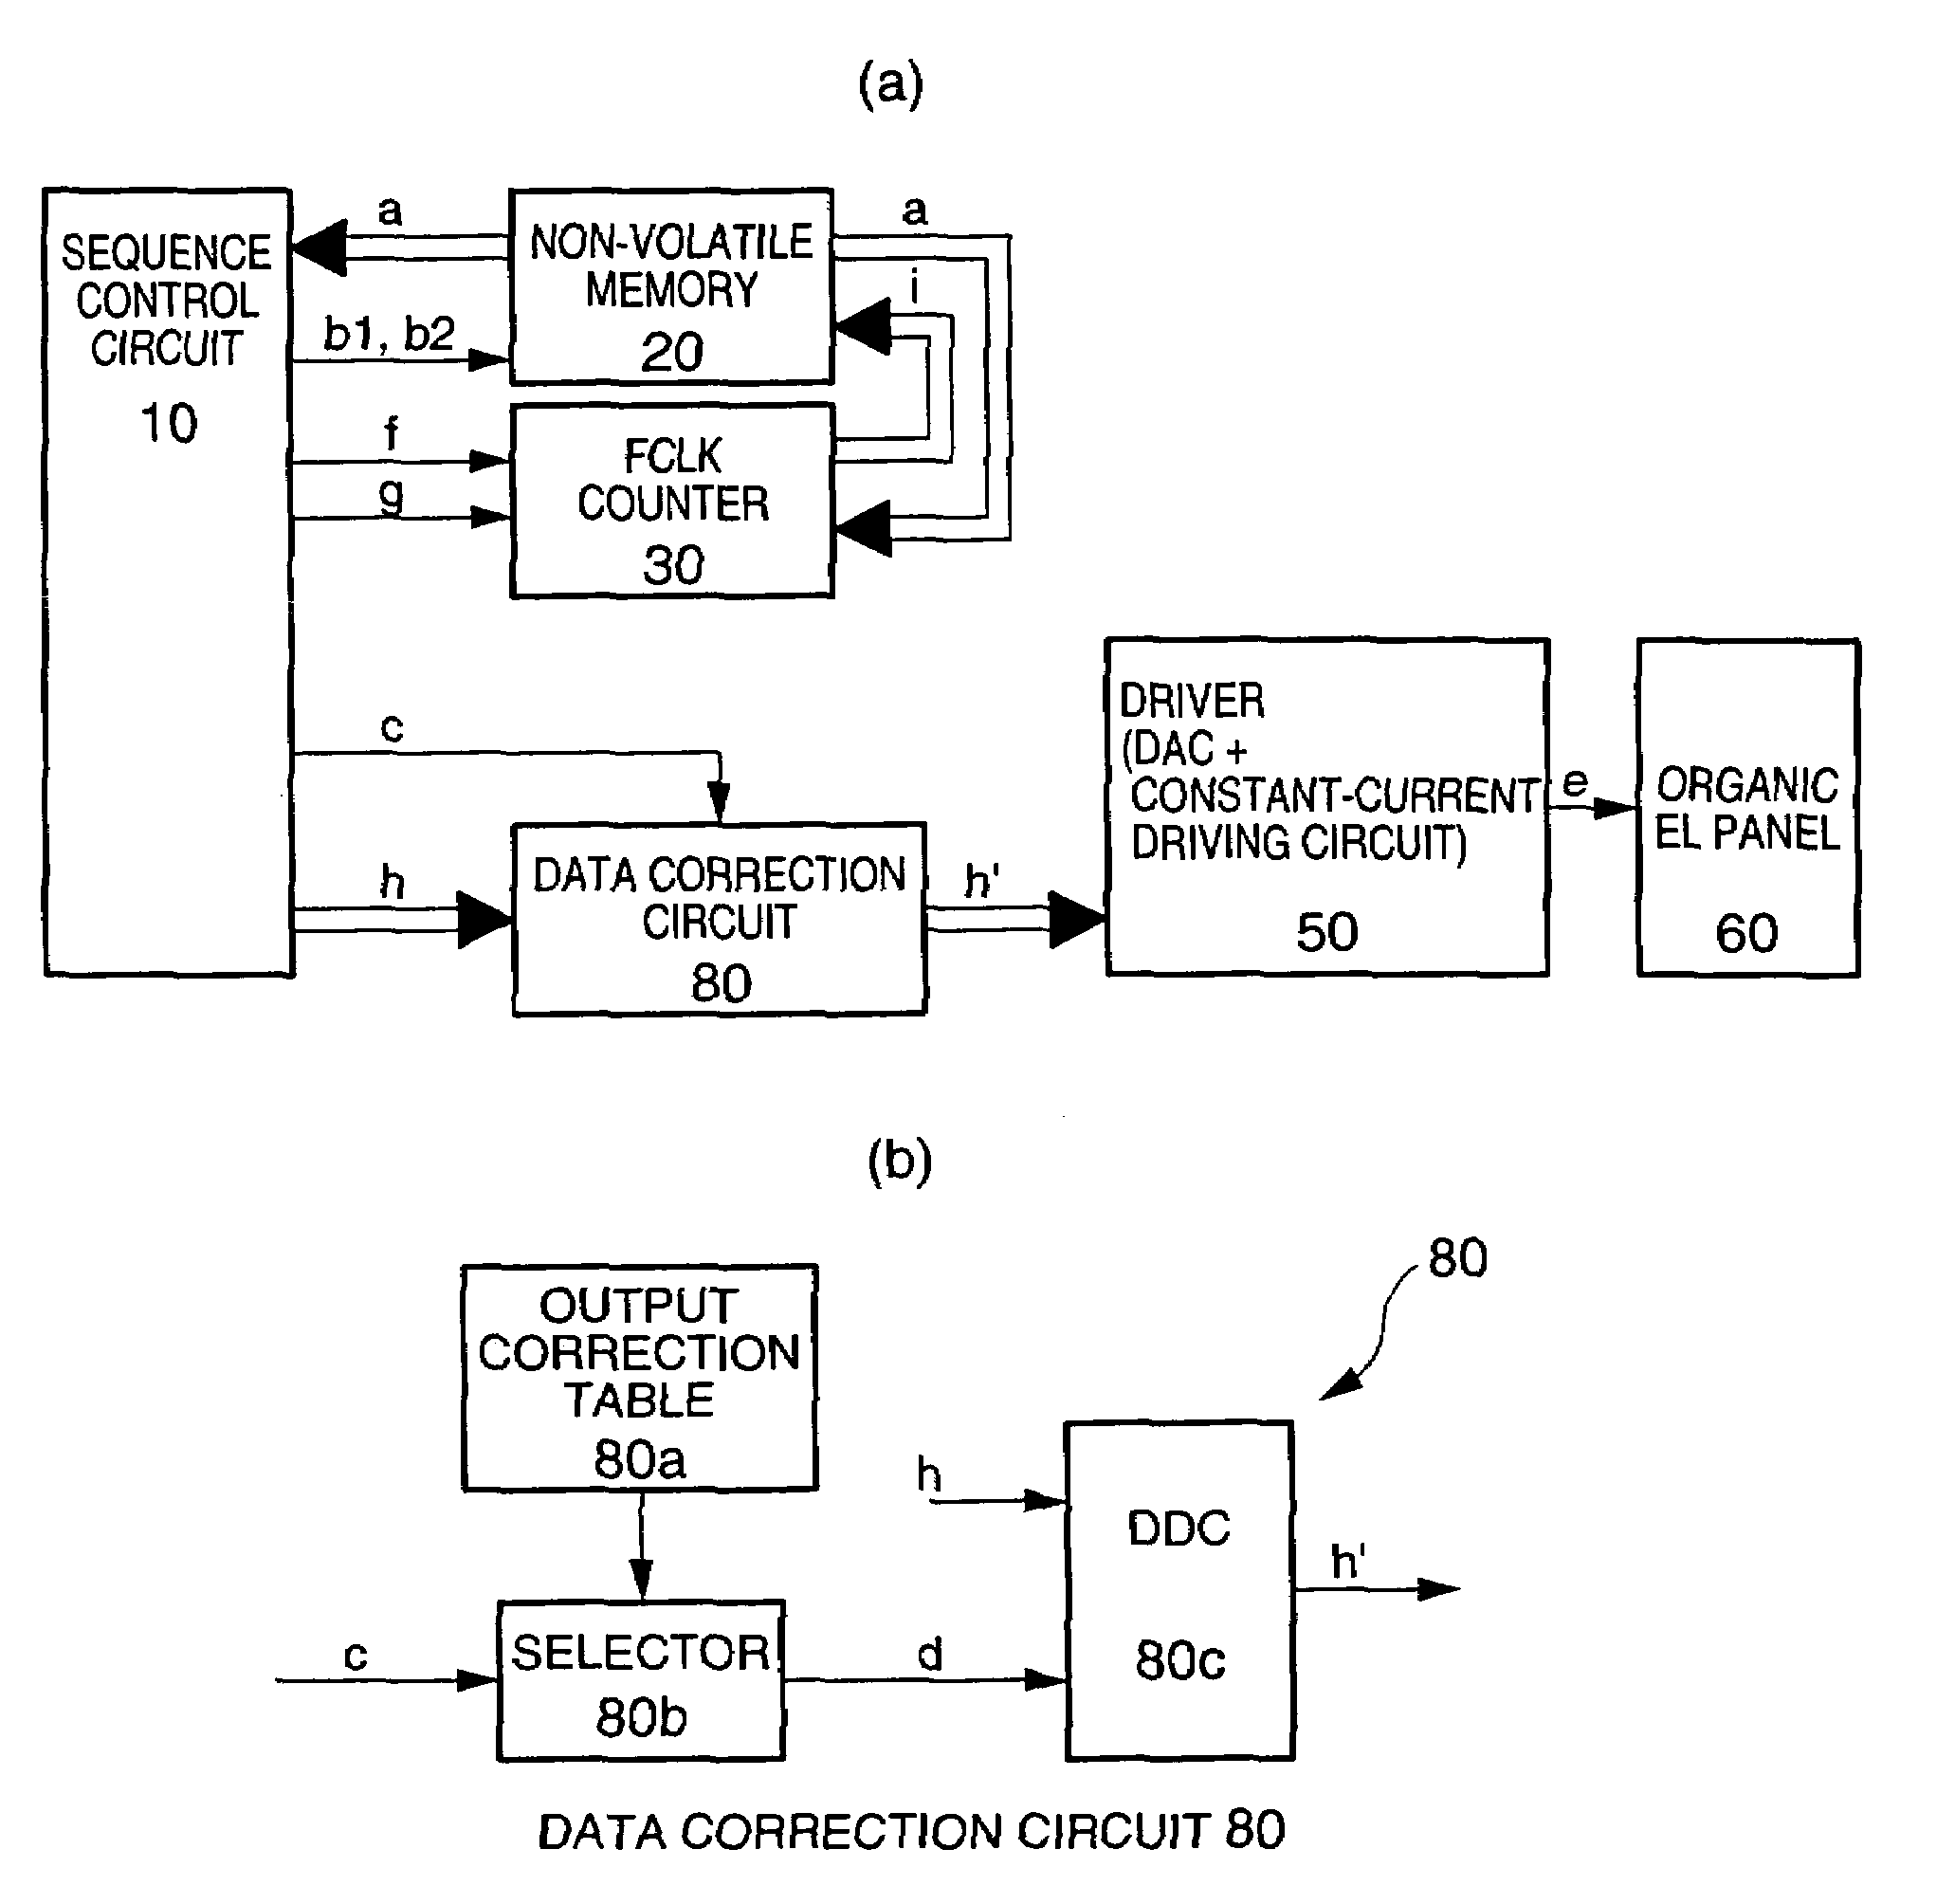
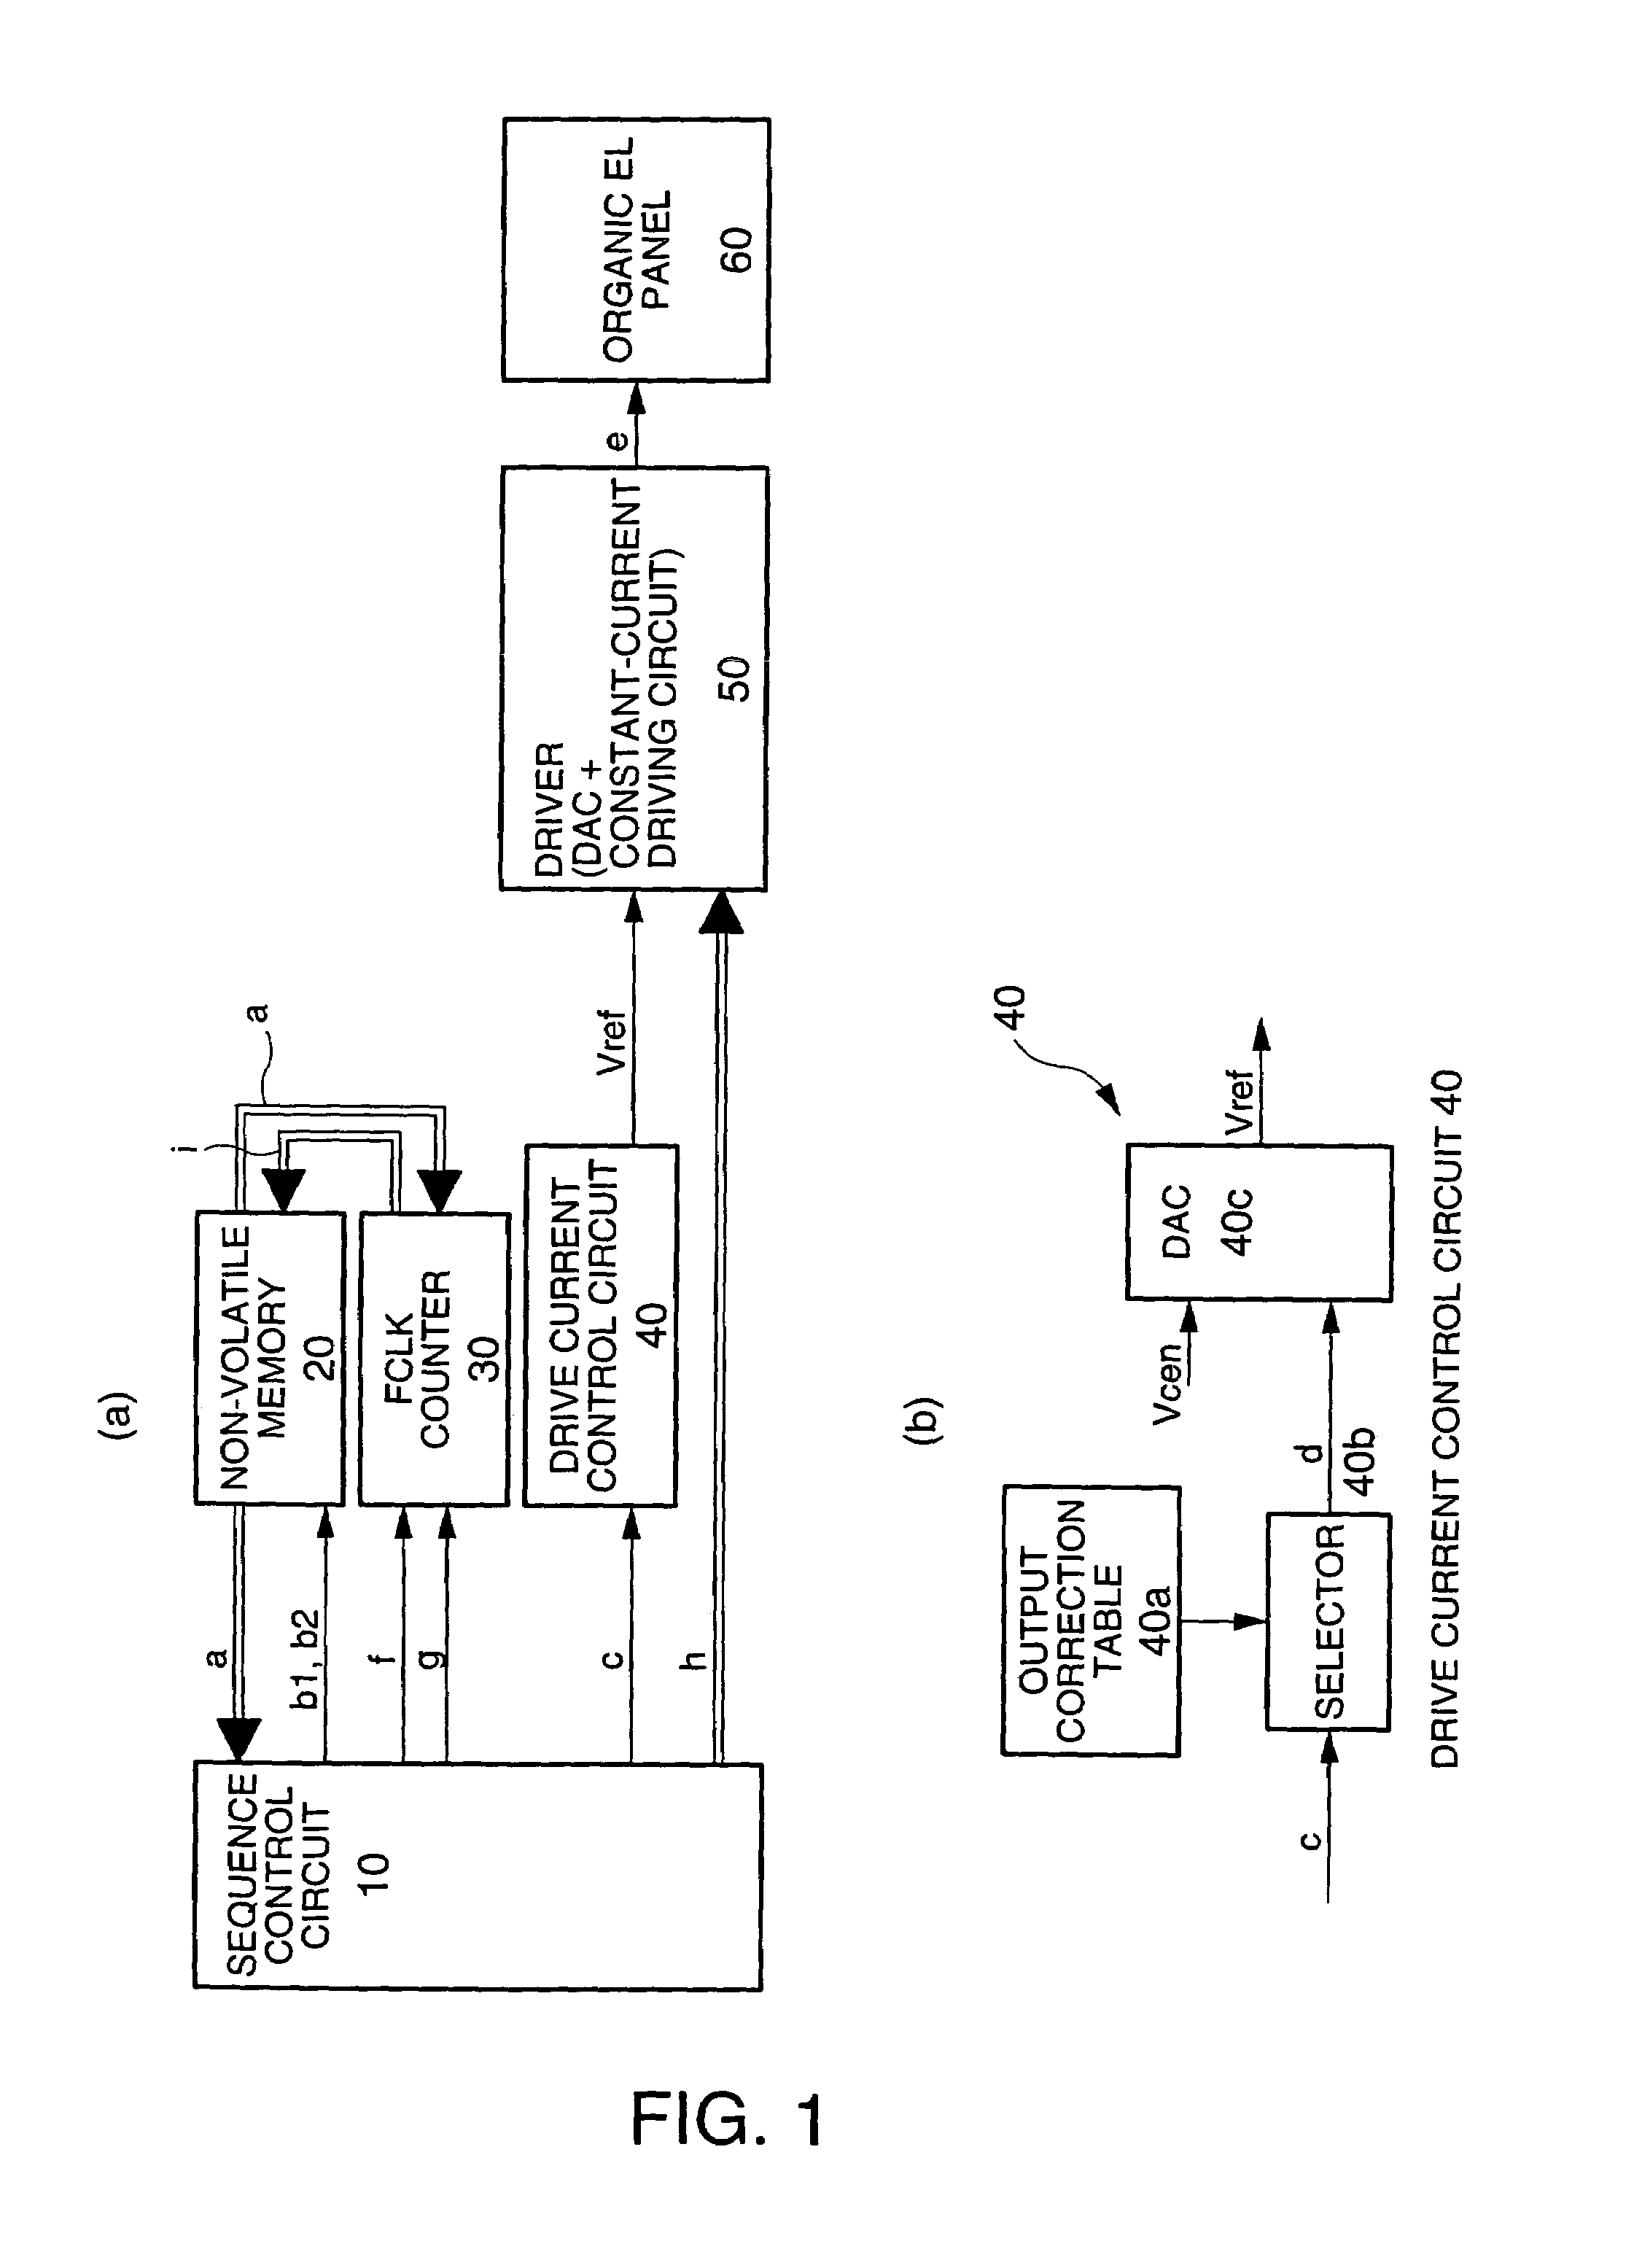
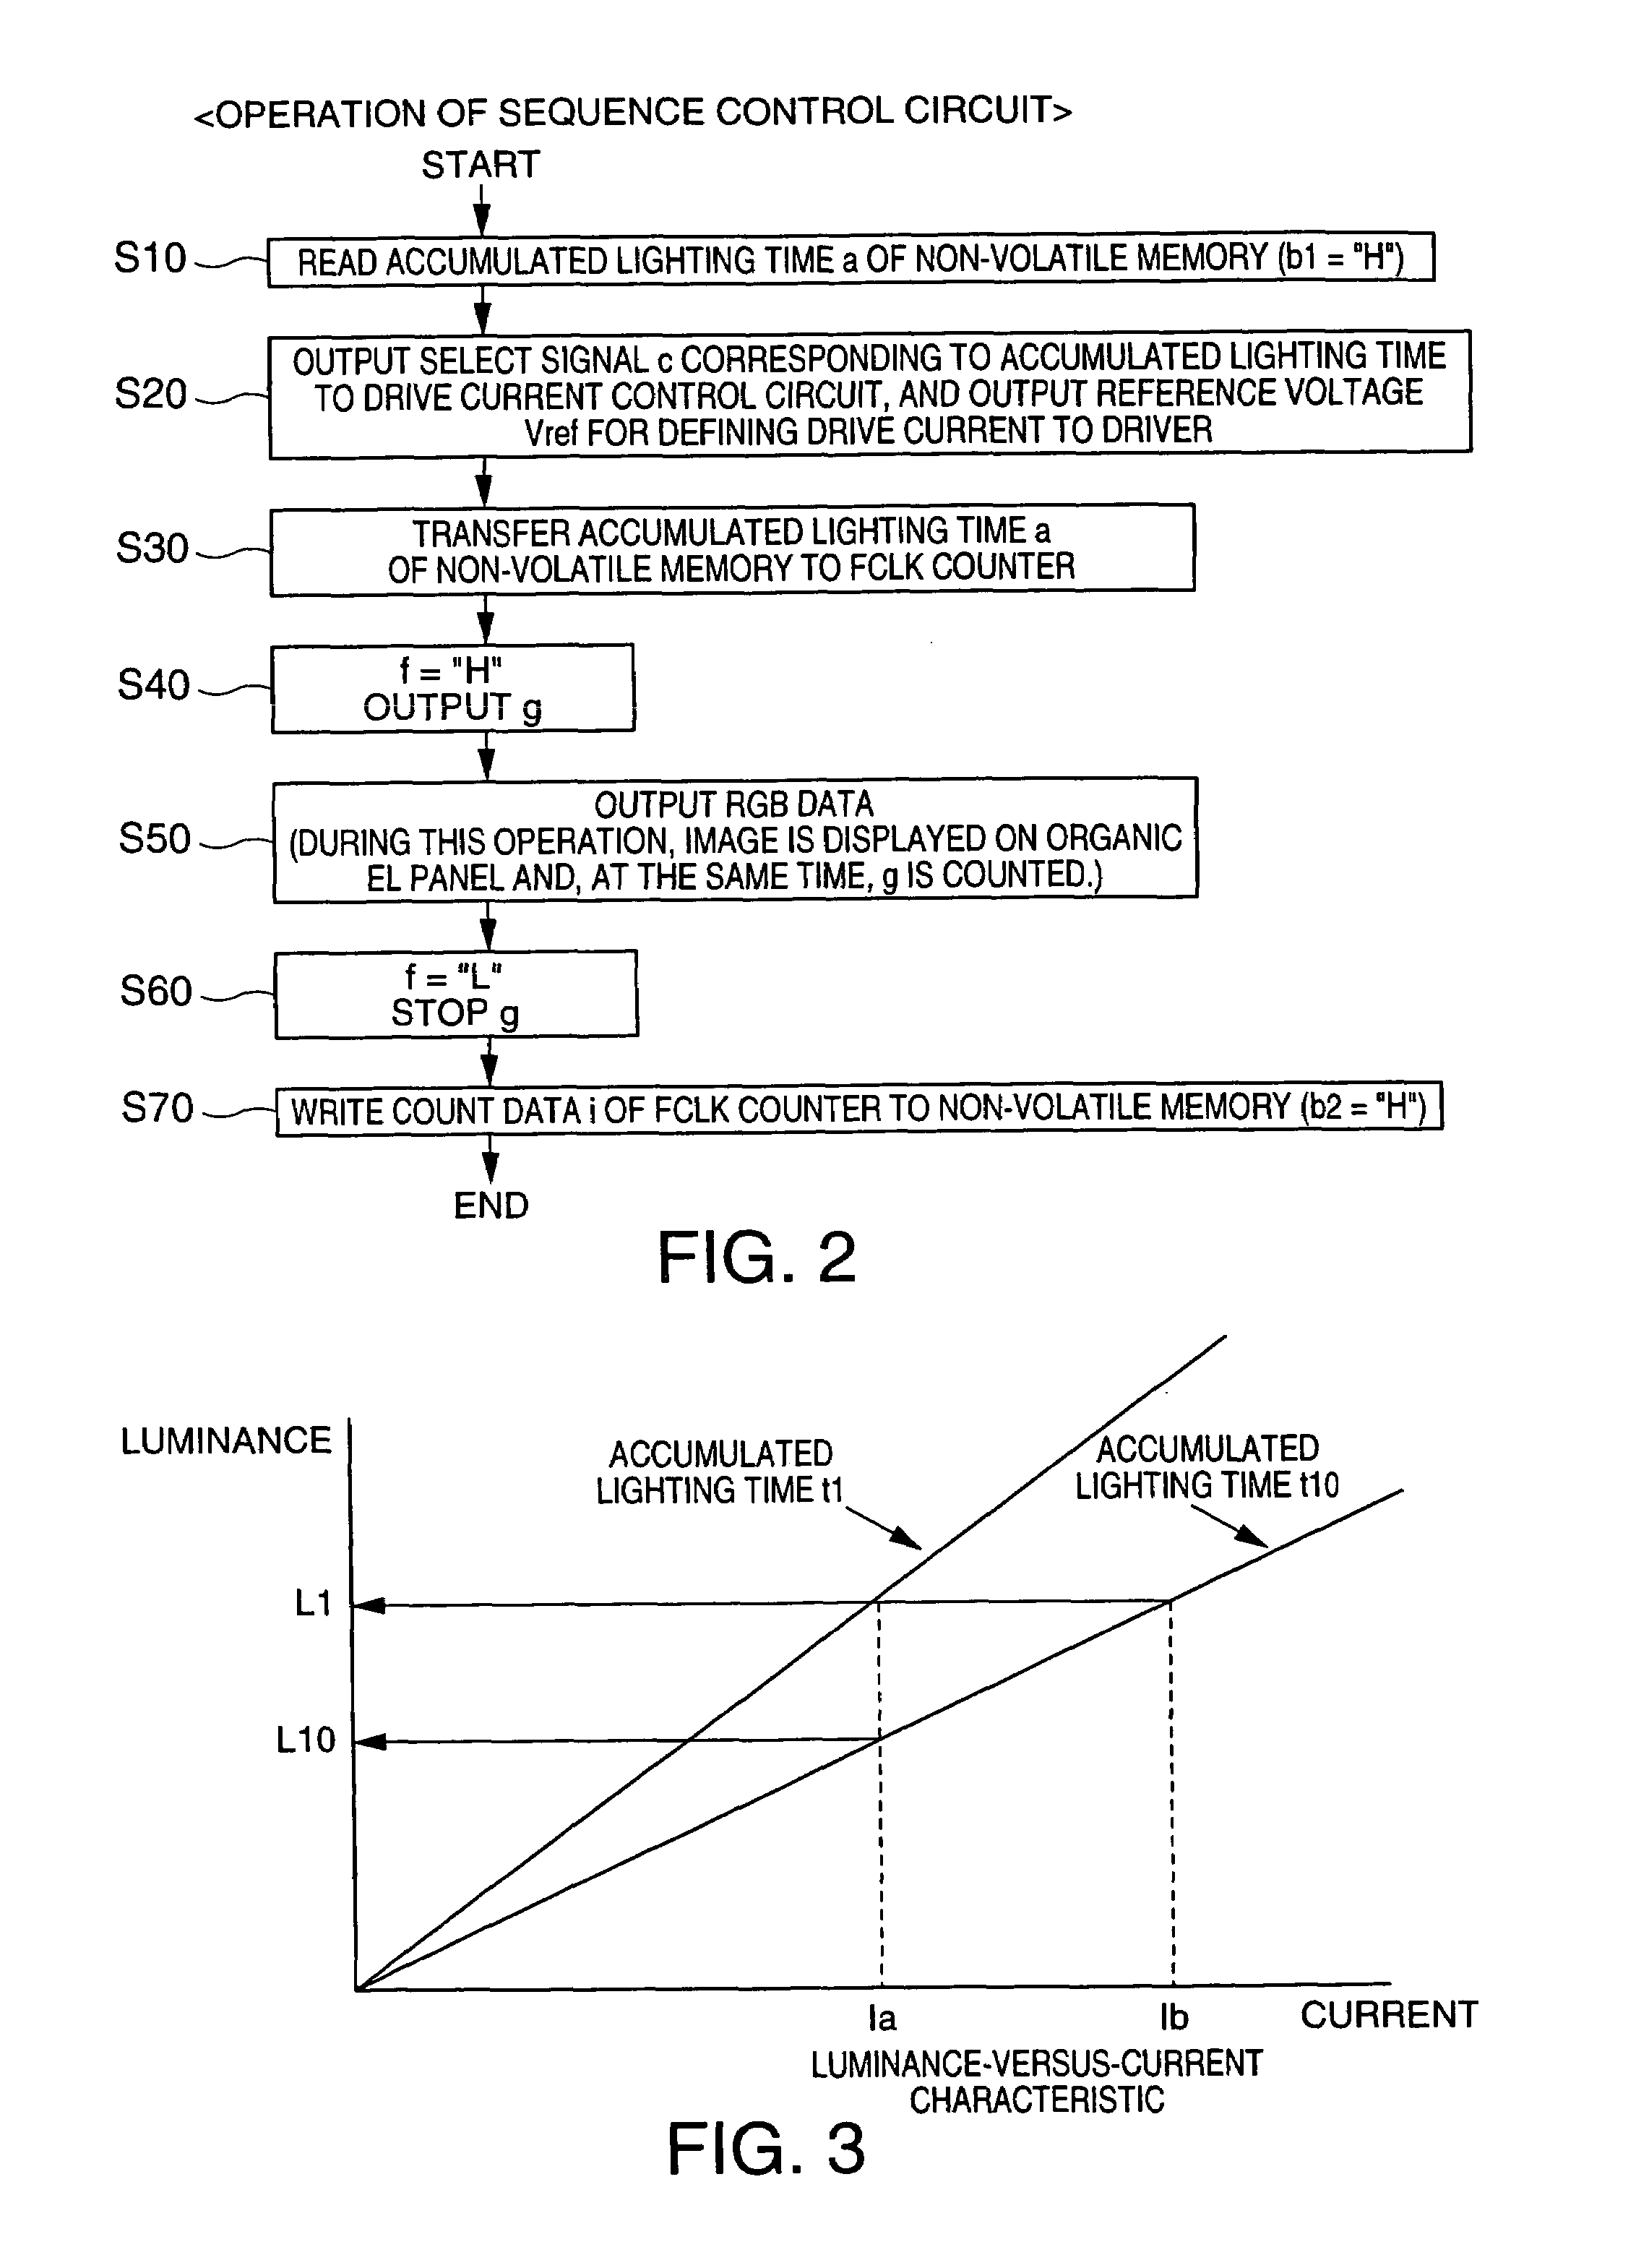
An electro-optical apparatus is provided that has a plurality of scanning lines, a plurality of signal lines, and electro-optical devices that are each being placed at an intersection of each of the scanning lines and each of the signal lines. The electro-optical apparatus is driven according to the amount of drive current supplied to the electro-optical devices. The electro-optical apparatus includes a lighting time measuring unit to measure a lighting time of the electro-optical devices, a lighting time storage unit to store the lighting time obtained by the lighting time measuring unit, and a drive current amount adjusting unit to adjust the amount of drive current based on the lighting time stored in the lighting time storage unit so as to correct the brightness of the electro-optical devices.
Owner:INTELLECTUAL KEYSTONE TECH LLC
Method and apparatus for device control, device, storage medium and program product
PendingCN120833453ACharacter and pattern recognitionImage data processingComputer hardwareLighting-up time
According to the embodiment of the invention, a method and device for device control, equipment, a storage medium and a program product are provided. The method comprises the following steps: controlling a light source at each positioner in a first group of positioners to execute lighting according to a first group of time sequences; controlling the light source at each positioner in the second group of positioners to be lightened according to a second group of time sequences, wherein the first group of time sequences and the second group of time sequences are configured to enable the lightening time of the light source at at least one positioner in the first group of positioners to be synchronized with the lightening time of the light sources at part of positioners in the second group of positioners; and controlling the image collector to execute image collection at least according to a third time sequence, wherein the third time sequence is configured to enable the image collector to execute image collection when at least one positioner in the first group of positioners and a part of positioners in the second group of positioners are synchronously lightened.

Owner:BEIJING ZITIAO NETWORK TECH CO LTD
Light source apparatus, image projection apparatus, and control apparatus that control multiple light sources at different lighting timings
ActiveUS11112688B2Reduce startup timeProjectorsPicture reproducers using projection devicesLighting-up timeFirst light
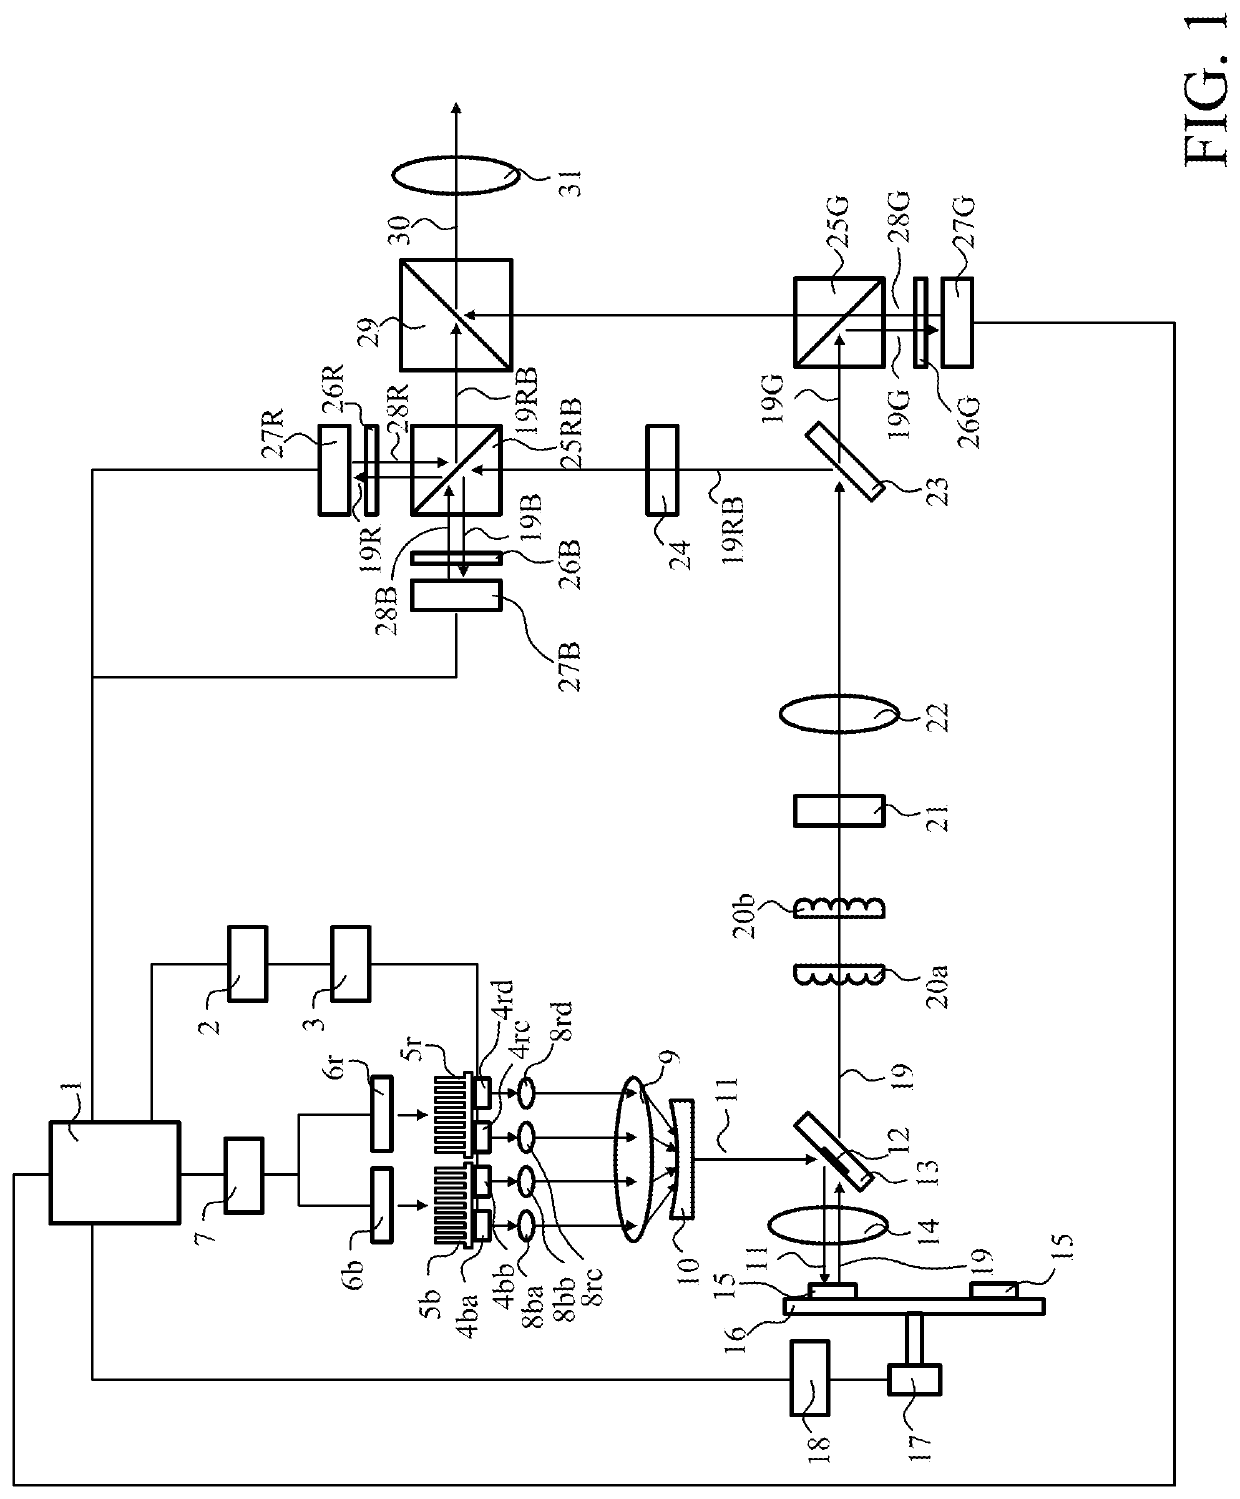
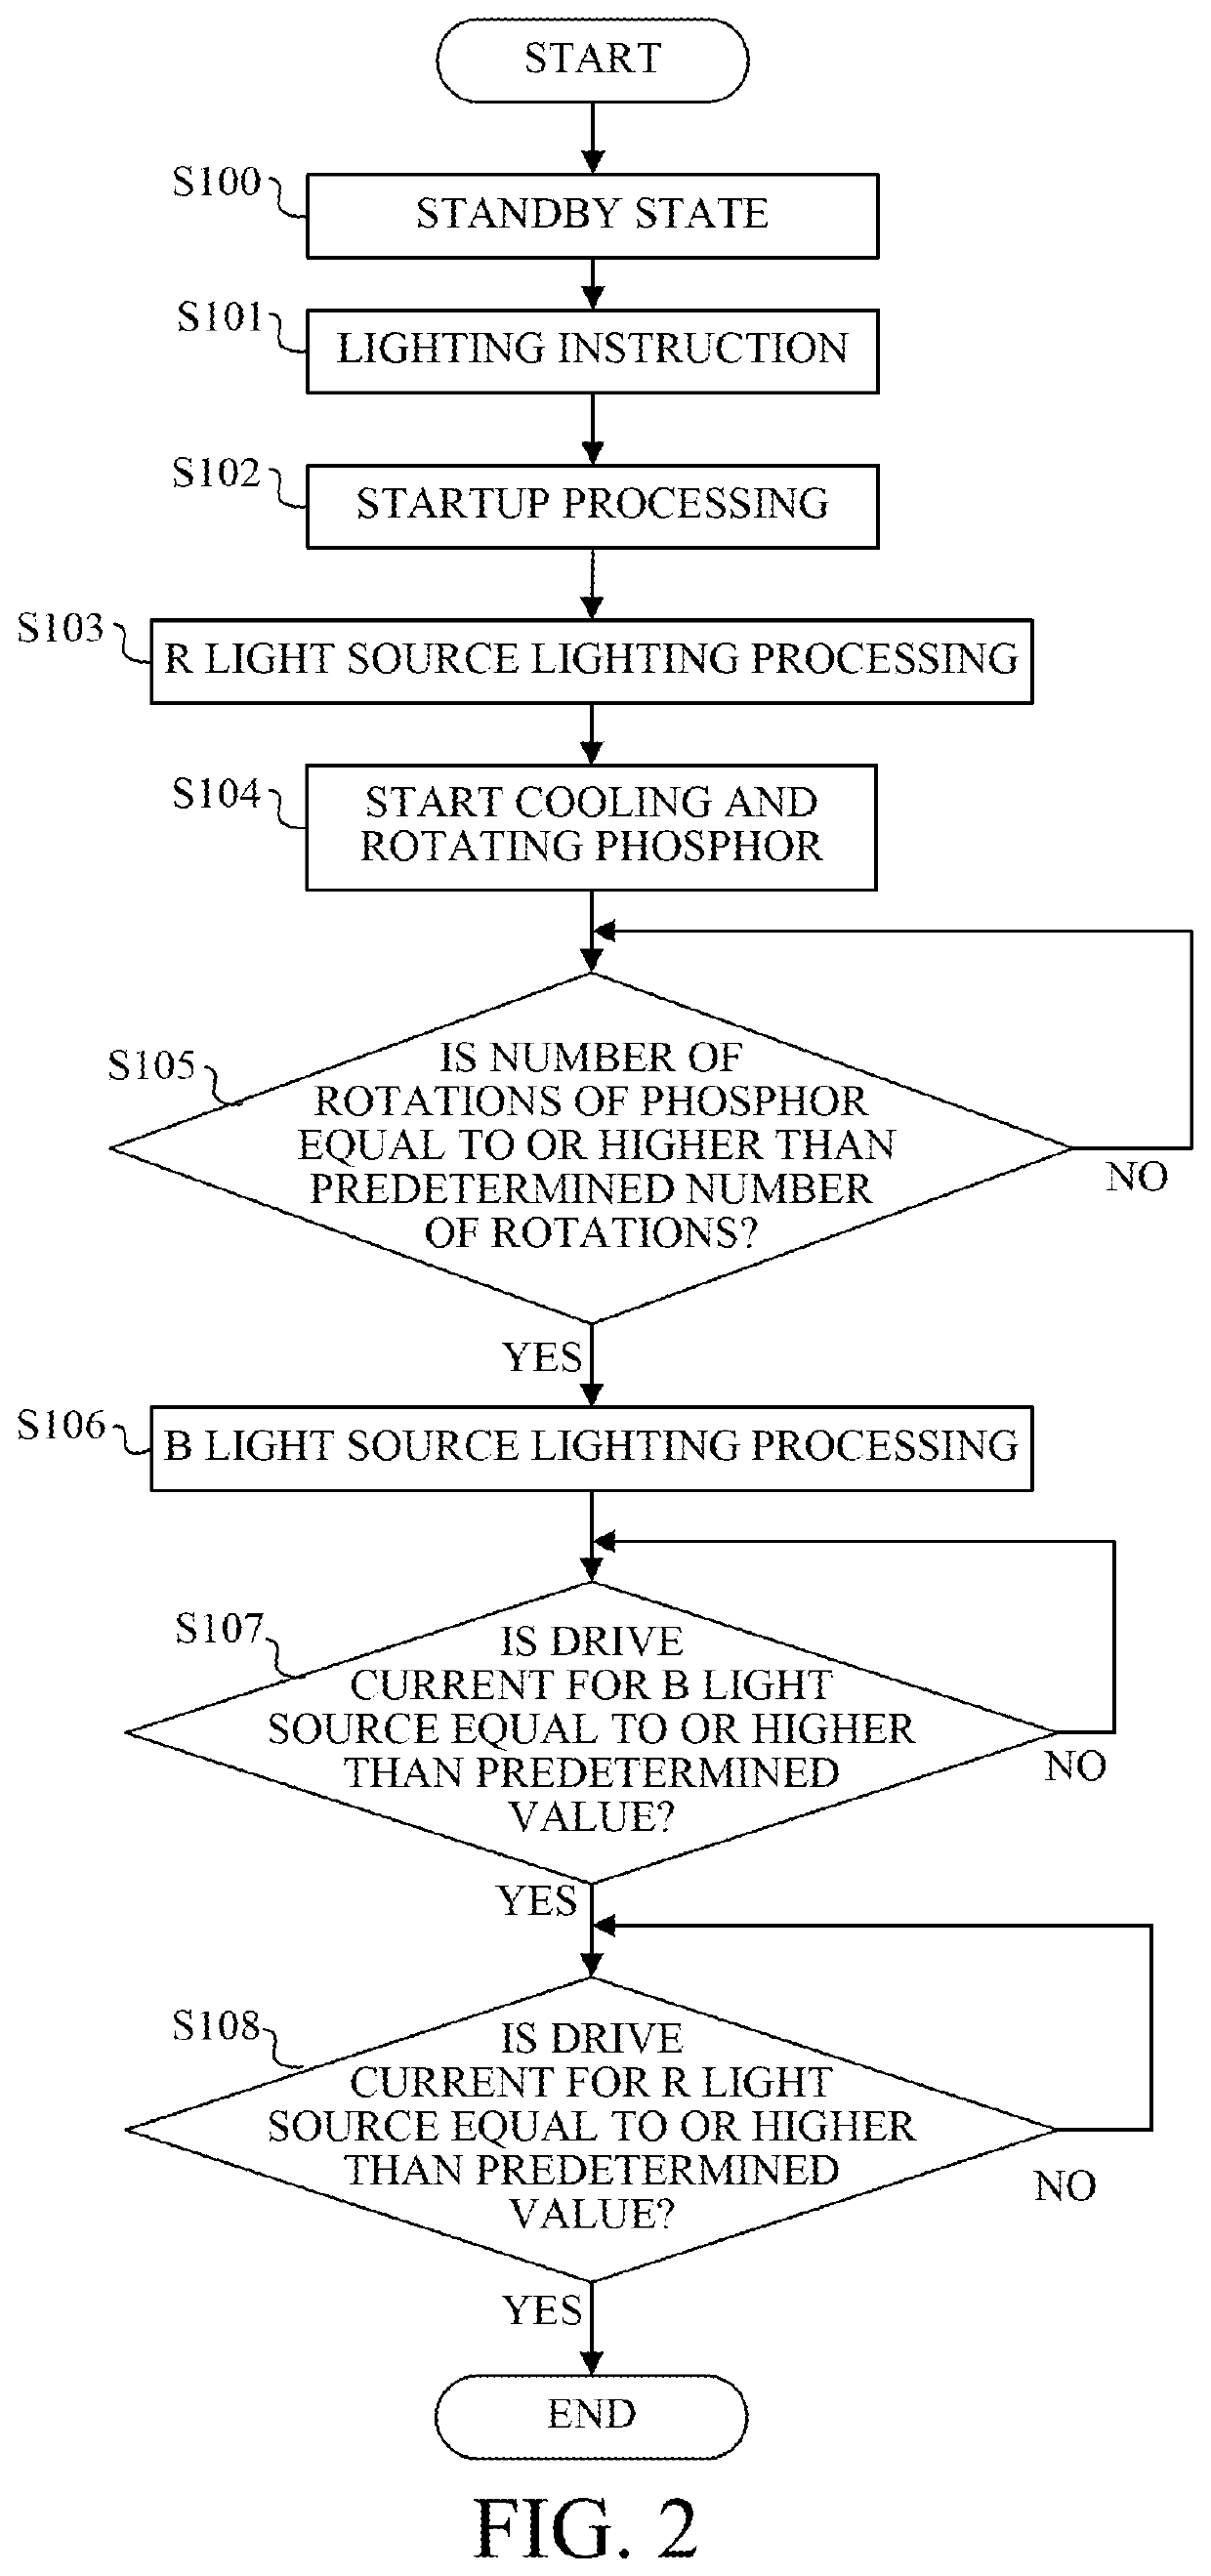
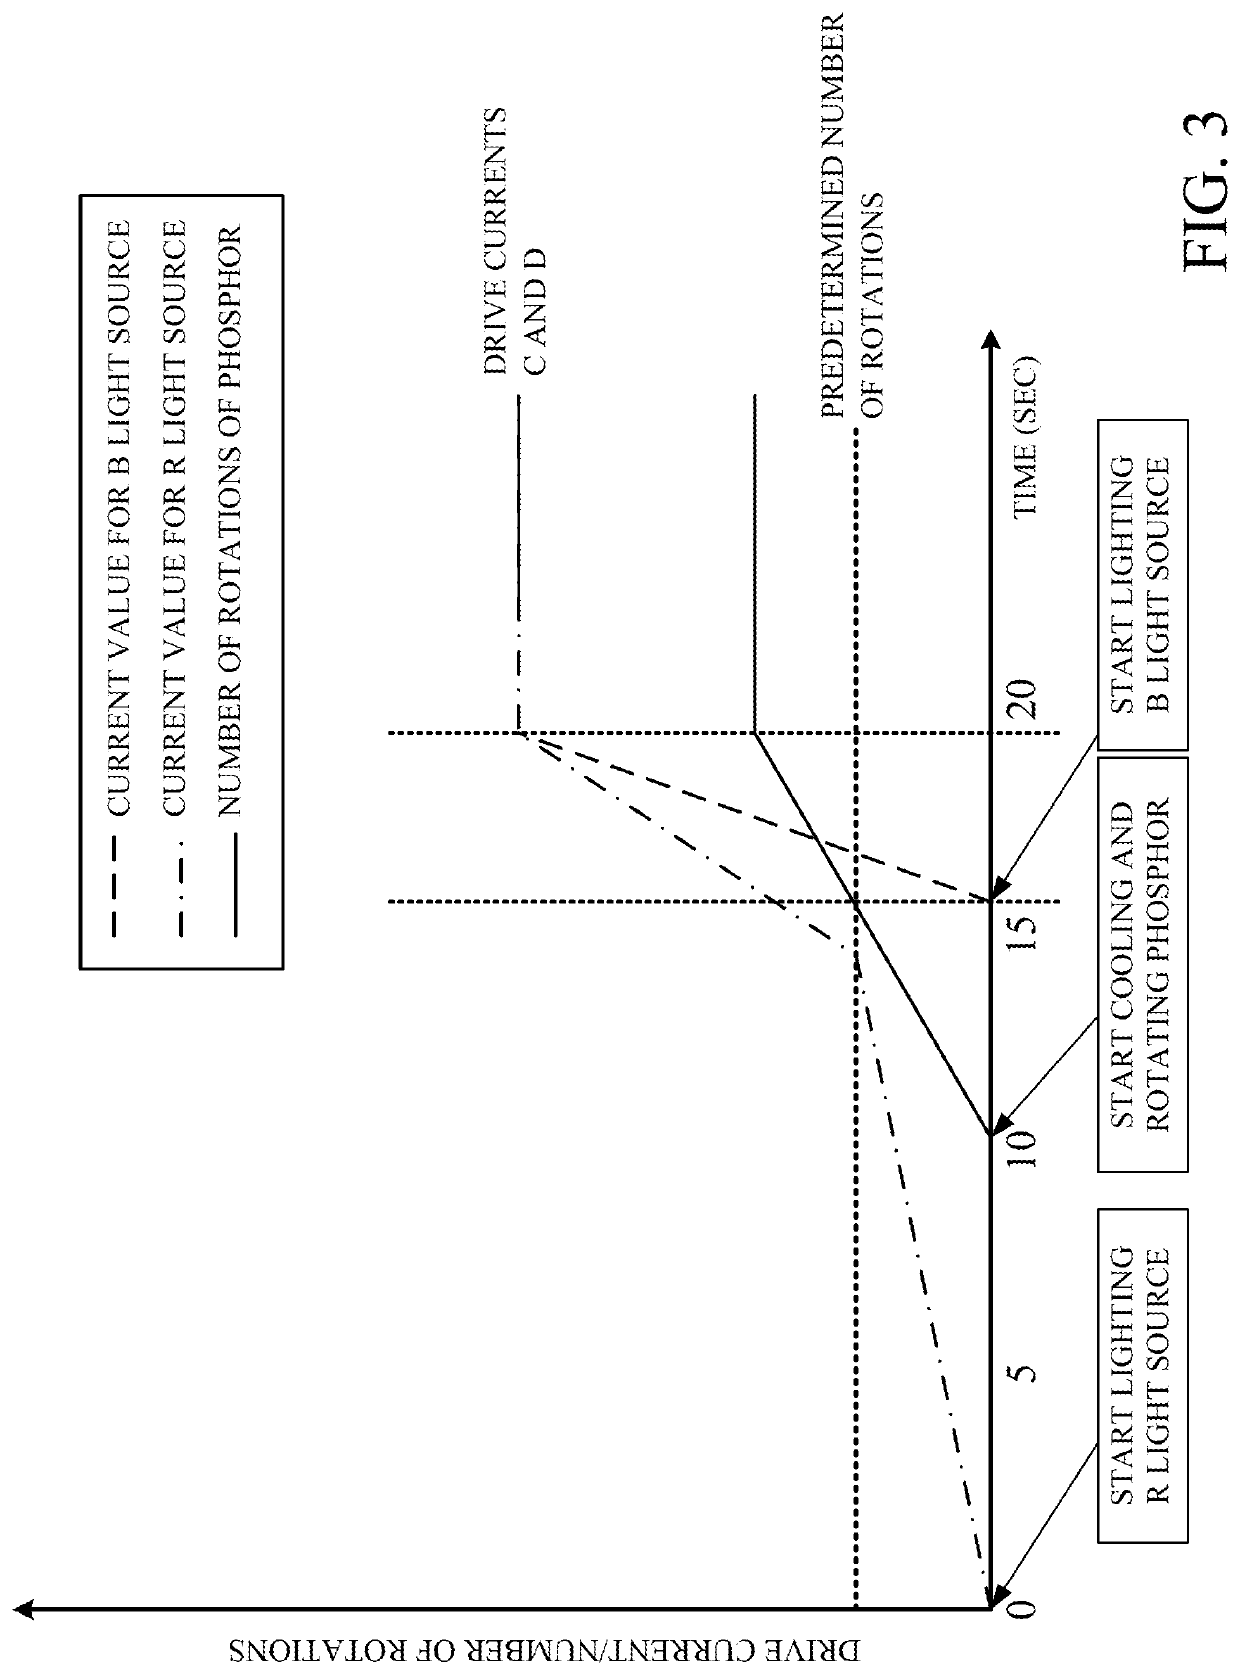
A light source apparatus includes a first light source, a second light source configured to emit light with a different wavelength than that of the first light source; and a controller for controlling each of the first and second light sources. The controller provides a control such that the second light source takes a longer time from a lighting start to a lighting completion than the first light source, and the second light source starts lighting earlier than the first light source.
Owner:CANON KK
Information processing device, lighting system, vehicle, and lighting control method
ActiveUS11153954B2Secure and safer societyVehicle headlampsElectrical apparatusComputer hardwareInformation processing
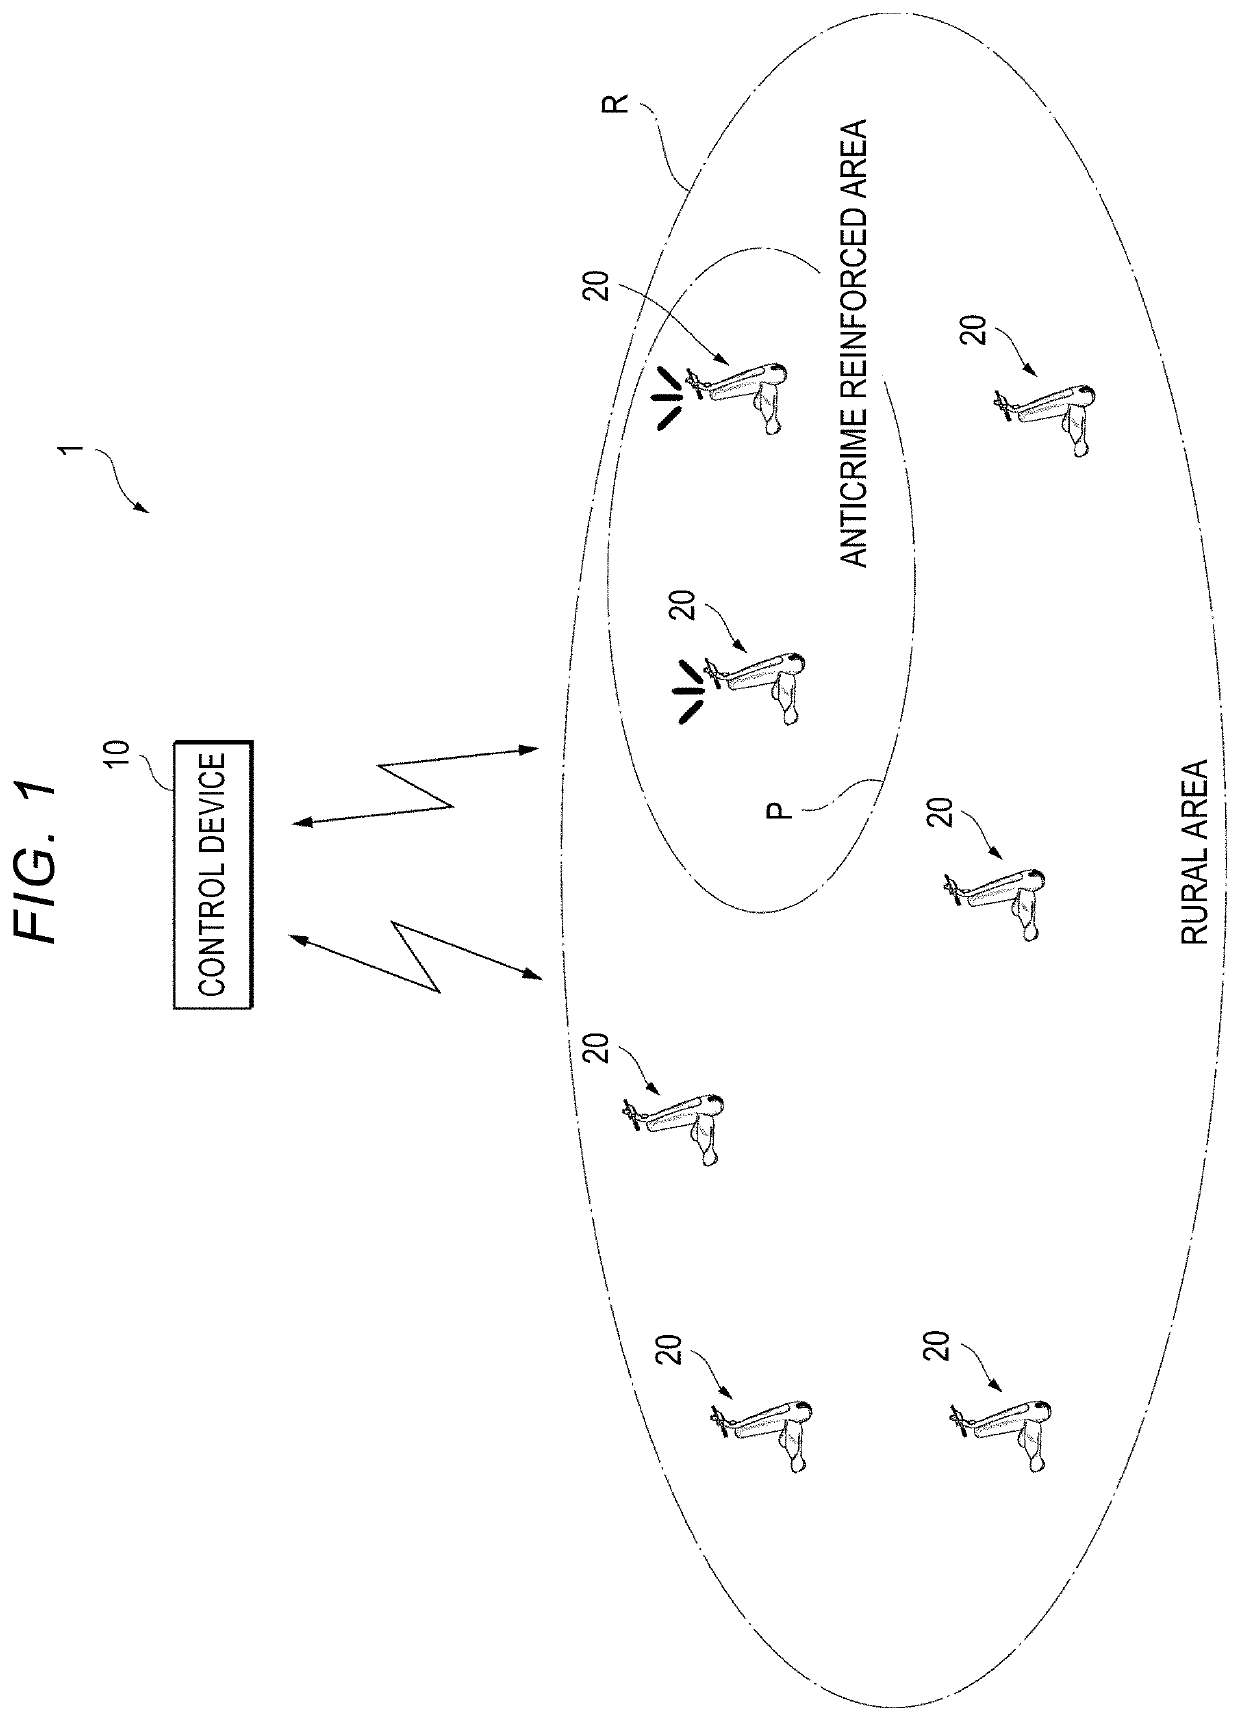
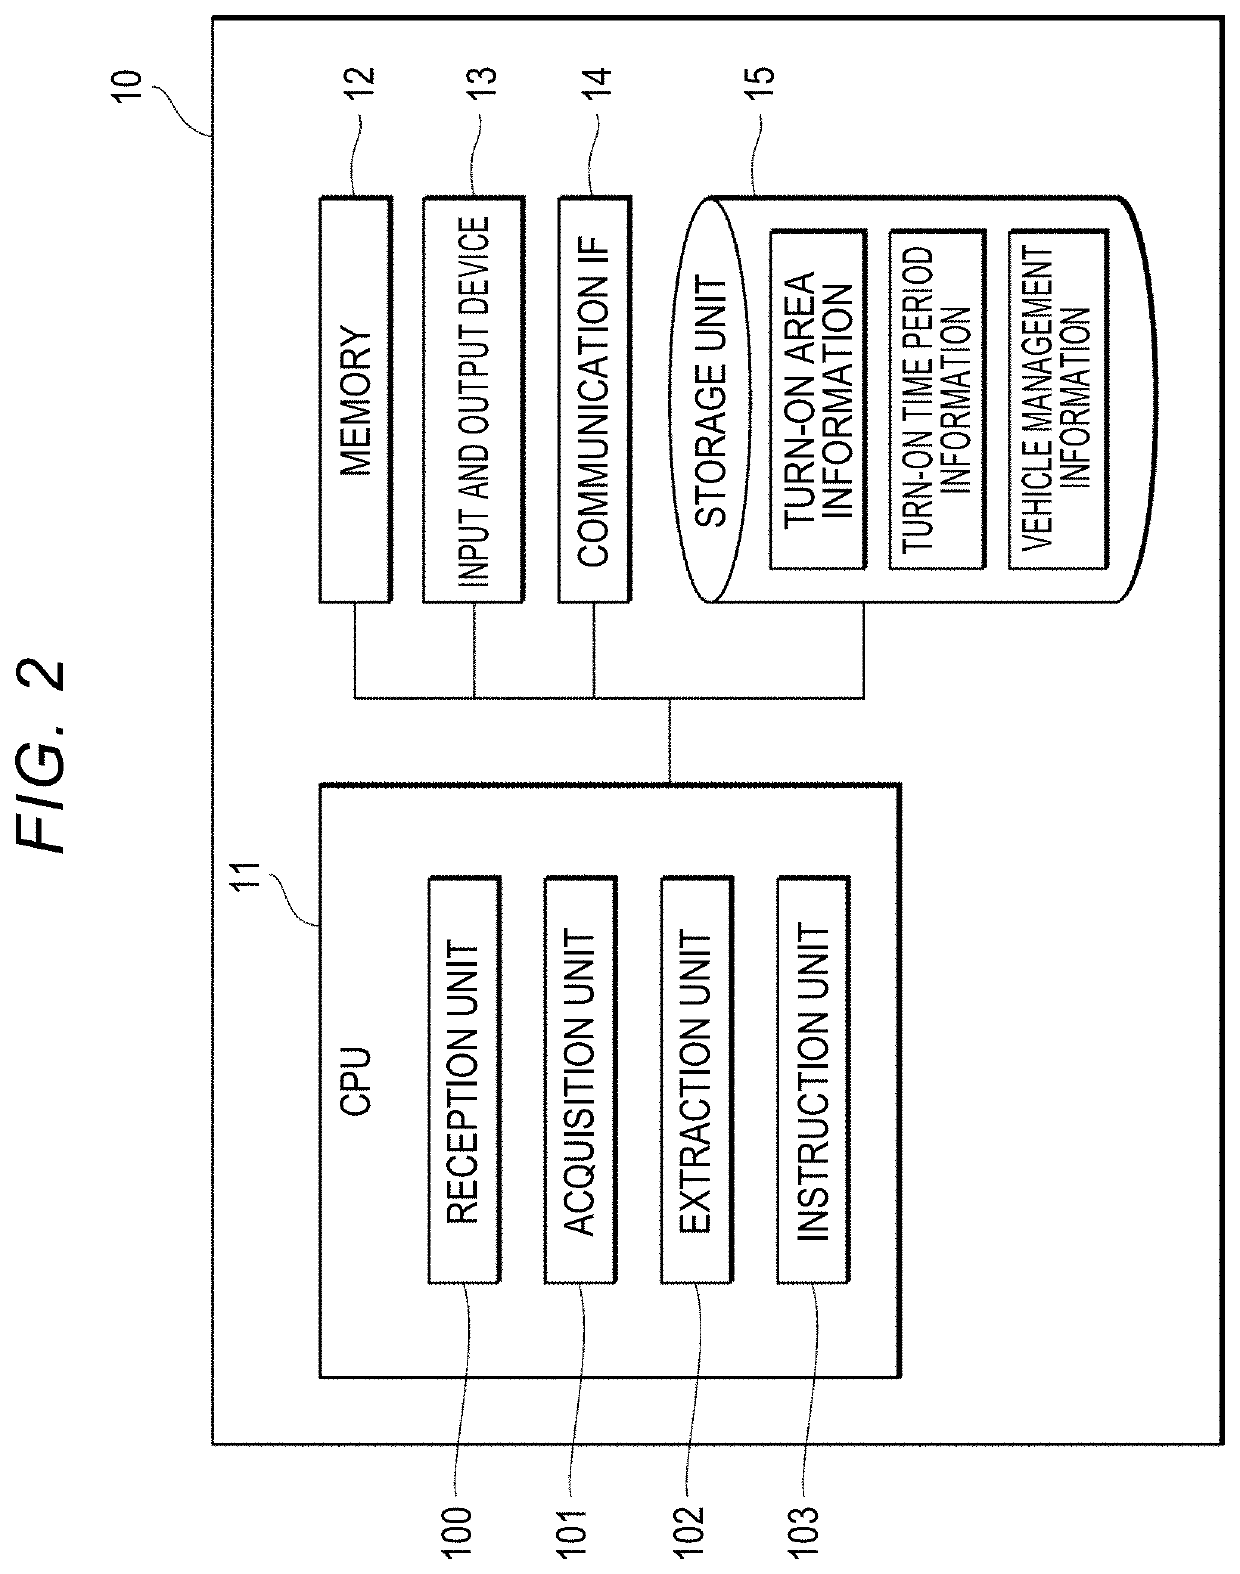
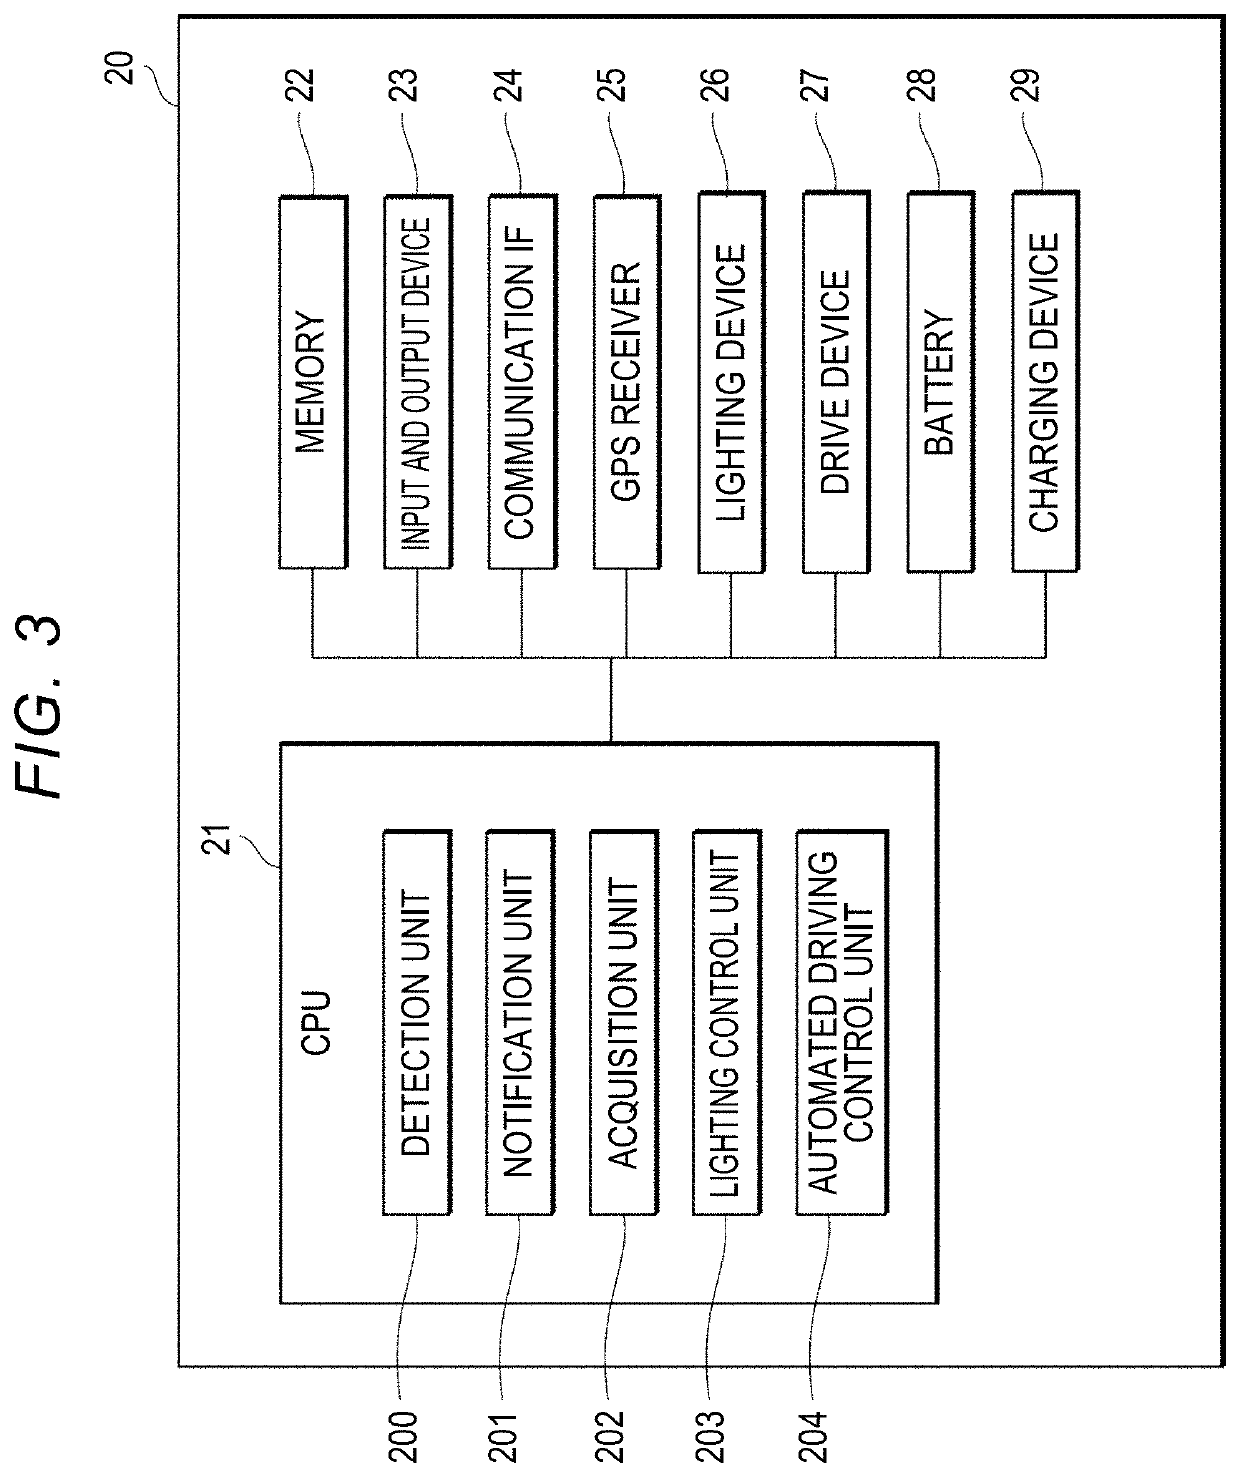
An information processing device includes a storage unit configured to store area information for designating an area in which a lighting device is to be illuminated and illuminating time period information for designating a time period in which the lighting device is to be illuminated; and a first processor configured to acquire a current position of each of a plurality of vehicles, to extract at least one vehicle of which the current position is in the area from among the plurality of vehicles, and to instruct the at least one extracted vehicle to illuminate the lighting device in the time period.
Owner:TOYOTA JIDOSHA KK