

Patents
Literature
42results about How to "Reduce detection delay" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Coordinated detection method of NDN low-speed cache pollution attack
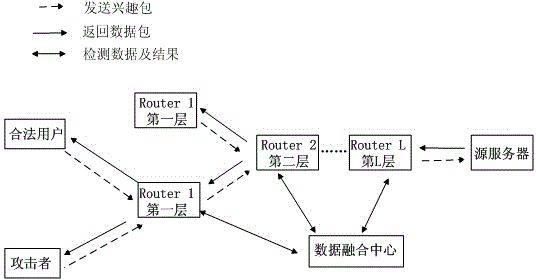
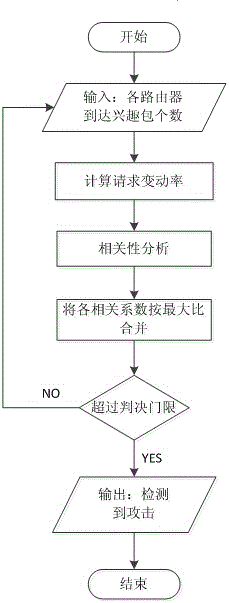
The invention discloses a coordinated detection method of an NDN low-speed cache pollution attack, which can be used for detecting attack behaviour through calculating multilayer node request change rates on a transmission path, thereby fusing nodes in each layer and correlation of request change rates of nodes in a first layer. The method of the invention can ensure high correct detection rate under occasion of the low-speed cache pollution attack, and simultaneously reduce detection delay of a dispersed attack by cooperating with more than three layers of routes. The method of the invention can be used for effectively detecting a low-speed concentrated attack and the dispersed attack simultaneously and improving detection performance by sacrificing space complexity. The method of the invention can be applied to detect a cache pollution attack of named data networking.
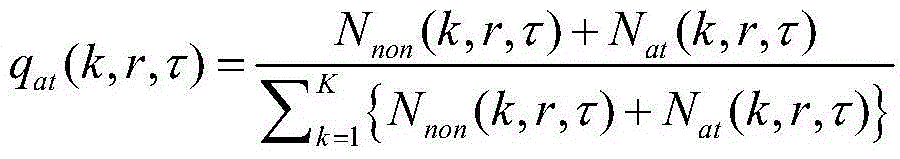
Owner:JIANGSU UNIV
Method for acquiring control resource sets, device, and system
PendingCN109511169AReduce detection delayReduce overheadTransmission path divisionSignal allocationTime domainInformation transmission
The application relates to the field of wireless communication, and provides a method for acquiring control resource sets. The method comprises the following steps that: a terminal device receives atleast one piece of indication information from a network device, wherein at least one piece of indication information is used to indicate a first time domain resource location, and the first time domain resource location is unavailable for control information transmission; the terminal device acquires a second control resource set according to at least one piece of indication information; and theterminal device detects the control information on the second control resource set. The method reduces the signaling overhead caused by the reconfiguration for the control resource sets by the high layer signaling, and reduces the control information detection delay.


Owner:HUAWEI TECH CO LTD
Adaptive qrd-m algorithm based signal detecting method by using constellation set grouping in spatial multiplexing multiple-input multiple-output system
ActiveUS20110044407A1Reduce detection delayReducing hardware demandPolarisation/directional diversityAmplitude-modulated carrier systemsConstellationMultiple input
There is provided a signal detecting method using constellation set grouping in a spatial multiplexing multiple input multiple output system. The signal detecting method includes dividing a set of candidate symbols, a constellation set into a plurality of subsets by grouping the constellation set; dividing a tree search process of a QR-decomposition with M-algorithm (QRDM) algorithm into a plurality of partial detection phases; and performing the plurality of divided partial detection phases in parallel or iteratively.


Owner:ELECTRONICS & TELECOMM RES INST
Method and device for detecting physical broadcast channel
ActiveCN102076018AReduce detection delayNetwork traffic/resource managementAssess restrictionBroadcast channelsTelecommunications
The embodiment of the invention provides a method and a device for detecting a physical broadcast channel. The method comprises the following steps of: collecting first wireless frame data; performing physical broadcast channel detection on the first wireless frame data; and finishing the current detection if the physical broadcast channel information is detected. By applying the embodiment of the invention, when the data is less than 40ms, the required physical broadcast channel (PBCH) information can be acquired by traversing and analyzing data at different positions in a PBCH Buffer. Undernormal condition, the PBCH information can be detected in 10ms, so the detection delay is greatly shortened, and guarantee is provided for other service operation, such as user equipment (UE) accessing, switching and the like.


Owner:SHANGHAI HUAWEI TECH CO LTD
Industrial product quality real-time monitoring method, equipment and system
InactiveCN110336845AQuick screeningReduce manufacturing costClosed circuit television systemsTransmissionMonitoring methodsImaging data
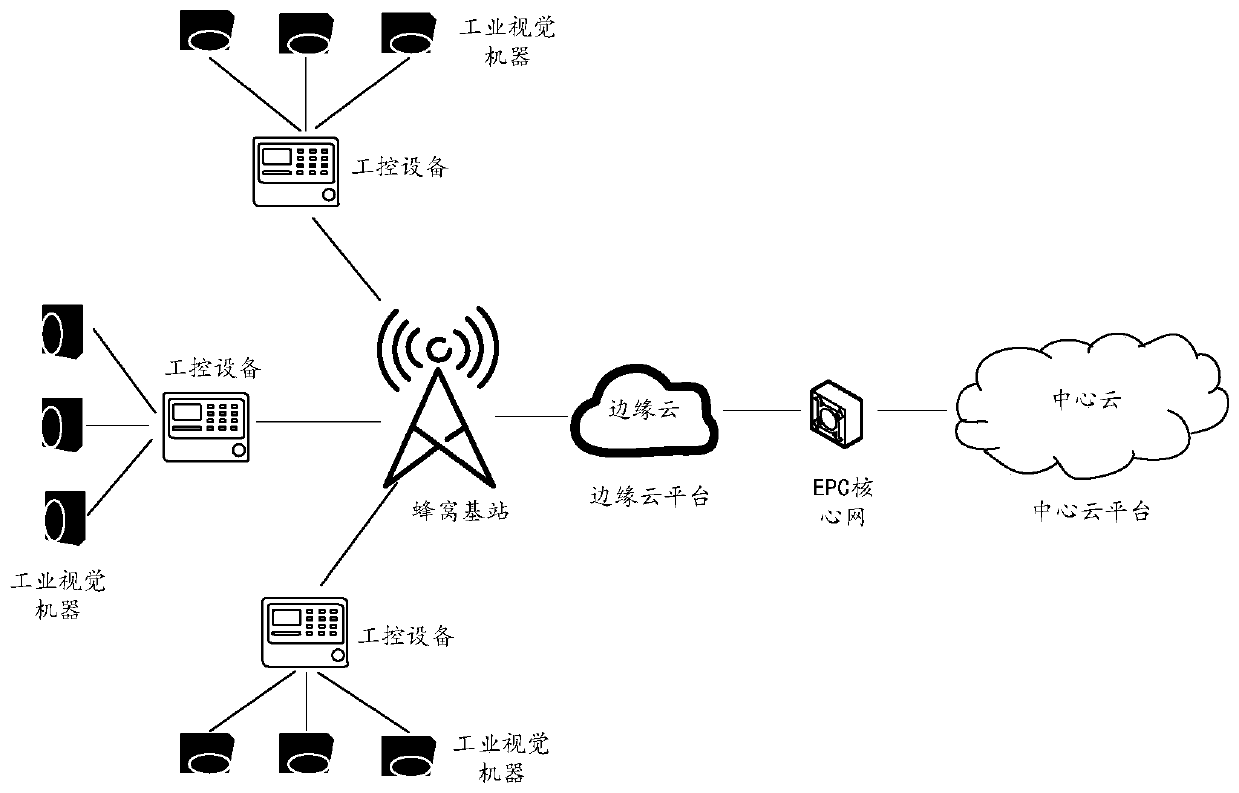
The invention provides an industrial product quality real-time monitoring method, equipment and system, relates to the technical field of networks, and aims to reduce the detection delay, facilitate industrial control equipment to quickly screen industrial products according to an analysis result of an edge cloud platform, improve the detection precision and the working efficiency and reduce the production cost of enterprises. The method is applied to an edge cloud platform, the edge cloud platform is in communication connection with industrial control equipment and a central cloud platform, and the method comprises the following steps: receiving image data of an industrial product sent by the industrial control equipment; receiving a detection model sent by the central cloud platform; utilizing the detection model to analyze and process the image data to obtain an analysis result; and feeding back the analysis result to the industrial control equipment to enable the industrial controlequipment to screen the industrial products according to the analysis result. The method is mainly used for monitoring the quality of industrial products in real time.
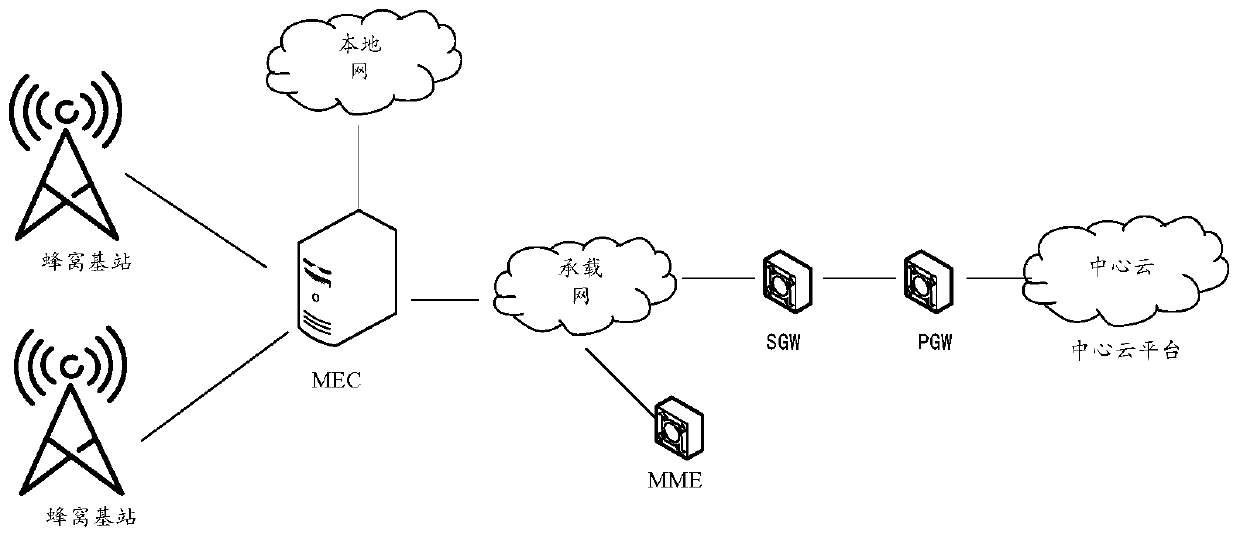
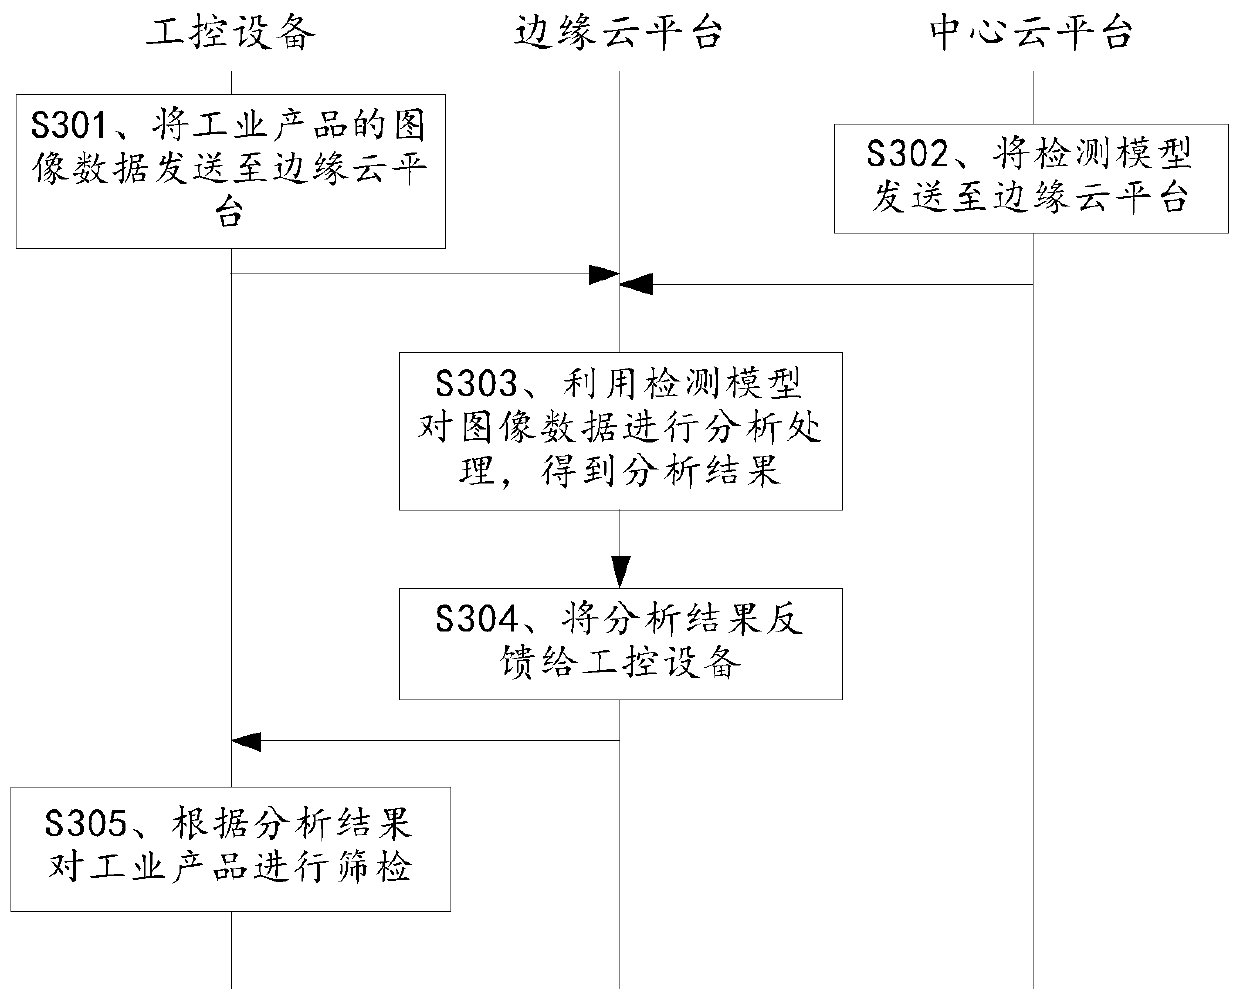
Owner:CHINA UNITED NETWORK COMM GRP CO LTD
Method and device for foreground object detection
ActiveCN105488542AImprove recognition efficiencyImprove consistencyCharacter and pattern recognitionForeground detectionObject detection
The invention provides a method and a device for foreground object detection. The device comprises a foreground area detection module, a foreground contour module, a gradient calculation module, and a foreground detection control module. The invention relates to the object identification field and particularly relates to the identification of the foreground object which moves irregularly. The method for the foreground object detection is performed according to the gradient change in the foreground contour masking area. In the prior art, the object moving in a single background Gaussian model is easy to identify as a background, and the object which has stopped for a while and then begins to move is usually identified as another object. The method disclosed by the invention improves the identification efficiency of the foreground object and the identification consistency.


Owner:福建星网物联信息系统有限公司
Sending and receiving methods, sending and receiving devices and transmission system for synchronizing signal
ActiveCN107634924ASolve problems that are too complexReduce Detection ComplexitySynchronisation arrangementTransmission monitoringComputer terminalComputer science
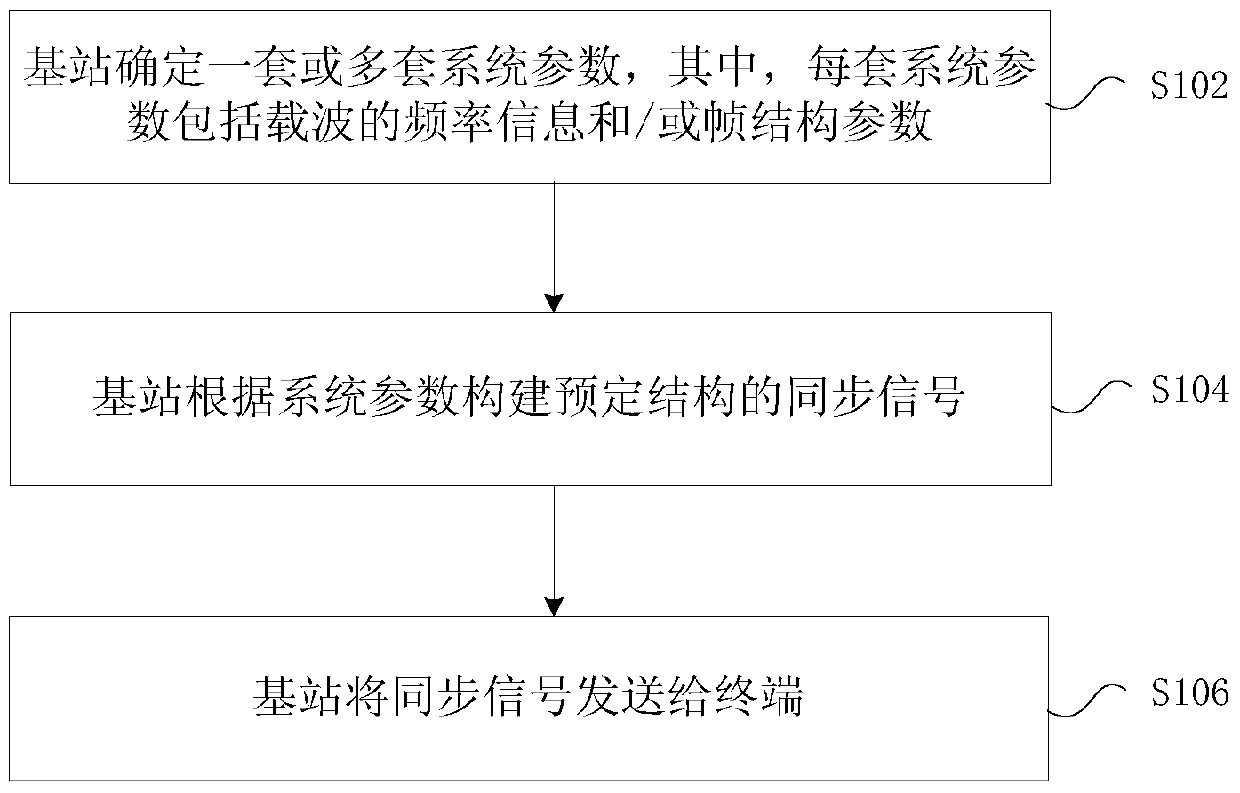
The invention provides sending and receiving methods, sending and receiving devices and a transmission system for a synchronizing signal. The sending method comprises the following steps that a base station determines one or more sets of system parameters, wherein each set of system parameters include frequency information of a carrier frequency and / or frame structure parameters of the carrier frequency; the base station constructs the synchronizing signal of a predetermined structure according to the system parameters; and the base station sends the synchronizing signal to a terminal, whereinone or more sets of system parameters are corresponding to the same predetermined structure. Through the sending and receiving methods, the sending and receiving devices and the transmission system for the synchronizing signal, a problem of high complexity during detection of the synchronizing signal in the prior art is solved.


Owner:ZTE CORP
Cognitive radio spectrum sensing method
InactiveCN105763273AQuick checkReduce detection delayTransmission monitoringFrequency spectrumComputer science
The invention provides a cognitive radio spectrum sensing method, belongs to the technical field of cognitive radio and relates to a rapid CUSUM detection technology. According to the cognitive radio spectrum sensing method, by further improving and applying a non-parameter CUSUM detection algorithm to spectrum detection, the shortcomings of an existing rapid detection method can be overcome under the conditions that no signal priori knowledge exists and signal appearing moment is random, and signals can be rapidly detected. The cognitive radio spectrum sensing method can dynamically adjust offset according to the detection situations and further shorten detection delay.


Owner:UNIV OF ELECTRONICS SCI & TECH OF CHINA
FPGA-based two-dimensional ordered statistical constant false alarm detector implementation method
ActiveCN111812632ASave resourcesAvoid cached readsRadio wave reradiation/reflectionShift registerParallel computing
The invention relates to the technical field of radar target detection, and in particular, relates to an FPGA-based two-dimensional ordered statistical constant false alarm detector implementation method. According to the method disclosed by the invention, detection is carried out in each clock period from two-dimensional power matrix input, so that the repeated reading time delay of the data cache is reduced, and the detection speed can be effectively improved. Aiming at the condition of large calculated amount in a traditional OS-CFAR (Ordered Statistical Constant False Alarm Rate) sorting process, the FPGA implementation method is completed by adopting parallel comparison, so that the sorting complexity is reduced. The reusability of a module is fully considered, two-dimensional slidingwindow structure setting is completed through a shifting register set, two-dimensional OS-CFAR detection is achieved, and BRAM memory resources and DSP resources of the FPGA can be saved.


Owner:UNIV OF ELECTRONICS SCI & TECH OF CHINA
SBC-oriented malformation SIP message detection method and system
InactiveCN104378373AImprove the protective effectFree from attackTransmissionComputer scienceData library
The invention provides an SBC-oriented malformation SIP message detection method and system, and belongs to the field of core network safety detection. The SBC-oriented malformation SIP message detection method comprises the steps that 101, a malformation SIP message detection module is added for the SBC, and a malformation SIP message database is built; 102, the SBC forwards the received SIP message to the malformation SIP message detection module, and the malformation SIP message detection module detects the SIP message; 103, the malformation SIP message detection module sends a replay message to the SBC according to the detection result; 104, the SBC is in communication with an IMS core network according to the message returned to the malformation SIP message detection module.


Owner:BEIJING UNIV OF POSTS & TELECOMM
Single-phase voltage sag quick detection method based on morphological filter and derivation method [Alpha][Beta]-dq transformation
InactiveCN109765420AAvoid noise effectsReduce detection delayCurrent/voltage measurementFault locationMorphological filterVoltage sag
The invention discloses a single-phase voltage sag quick detection method based on a morphological filter and derivation method [Alpha][Beta]-dq transformation. The method comprises the following steps that: S1: adopting a structural element of which the cosine shape and the triangle are combined according to a certain ratio to carry out primary filtering on a detected single-phase voltage signal;S2: using a signal subjected to primary filtering through a combined-form filter for derivation, and constructing [Alpha][Beta] phase voltage; S3: using a cosine-form filter to filter noise signal interference amplified by differentiate operation; S4: on the basis, through dq transformation, using a linear type filter to filter a non-direct-current amount from a dq transformation result; and S5:calculating the amplitude and the phase angle of voltage sag. By use of the method, the amplitude, the time of duration and the phase change of the voltage sag can be quickly and accurately detected.


Owner:NORTHEAST DIANLI UNIVERSITY
Method and device for switching overtime period, and communication equipment
ActiveCN107204888AReduce downtimeReduce detection delayData switching networksTime switchingEngineering
The invention discloses a method and device for switching an overtime period, and communication equipment. When a transmission link between first communication equipment and second communication equipment has other communication equipment, the first communication equipment can switch a long overtime period into a short overtime period, thereby improving the link detection efficiency, and timely carrying out the corresponding processing to reduce the cutoff time of the communication equipment when the transmission link has an accident. The method comprises the steps that the first communication equipment determines whether the transmission link between the first communication equipment and the second communication equipment has third communication equipment or not; the first communication equipment enables the overtime period for detecting the transmission link to be switched to a second overtime period from a first overtime period when the transmission link has third communication equipment, wherein the first overtime period is greater than the second overtime period.


Owner:HUAWEI TECH CO LTD
MIMO-based signal detection method and detection platform
InactiveCN103929381AReduce detection delayImprove versatilitySpatial transmit diversityTransmitter/receiver shaping networksGeneral purposeRound complexity
The invention discloses a MIMO-based signal detection method. The method comprises: a detection platform receiving a signal r and a channel estimation matrix H through multiple antennas; and the detection platform, according to the received signal r and the channel estimation matrix H, performing parallel processing by use of a single instruction multiple data (SIMD) instruction set, and obtaining a UE sending sequence. According to the invention, the parallel processing of MIMO detection is realized by use of a SIMD instruction, therefore, high-complexity operation including matrix inversion, vector multiplying and the like can be avoided, and detection time delay is reduced. Besides, since the method and platform are realized based on a general-purpose processor (GPP), the versatility is quite good, and manpower resources can be saved.


Owner:CHINA MOBILE COMM GRP CO LTD
Active power filter direct current control method suitable for condition of weak power grid
InactiveCN104993495AGuaranteed dynamic performanceEffective compensationReactive power adjustment/elimination/compensationReactive power compensationVIT signalsPower inverter
The invention discloses an active power filter direct current control method suitable for the condition of a weak power grid. The method is implemented according to the following steps: Step 1. voltage of a PCC point of a weak power grid system, inverter direct current side voltage, an instantaneous value of load current and an instantaneous value of current emitted by the inverter are collected; Step 2.the collected instantaneous values and the instantaneous value of current emitted by the inverter are processed through a conditioning circuit and is input to a DSP to be converted to digital signals; Step 3. the DSP processes the digital signals to obtain instruction current signals of the active power filter; Step 4. the DSP performs hysteresis comparison on the instruction current signals and the digital signals, and is controlled to emit PWM waves; and Step 5. the emitted PWM waves are sent to a drive circuit of an IGBT module of the inverter, the inverter is controlled to emit current according to the instruction current signals, and harmonic waves and reactive power in a power grid system are compensated according to the emitted current. The active power filter direct current control method suitable for the condition of the weak power grid effectively and accurately compensates reactive current and harmonic current of a load.


Owner:XIAN UNIV OF TECH
Integrated detection method of edge side cloned node based on counterpropagation neural network
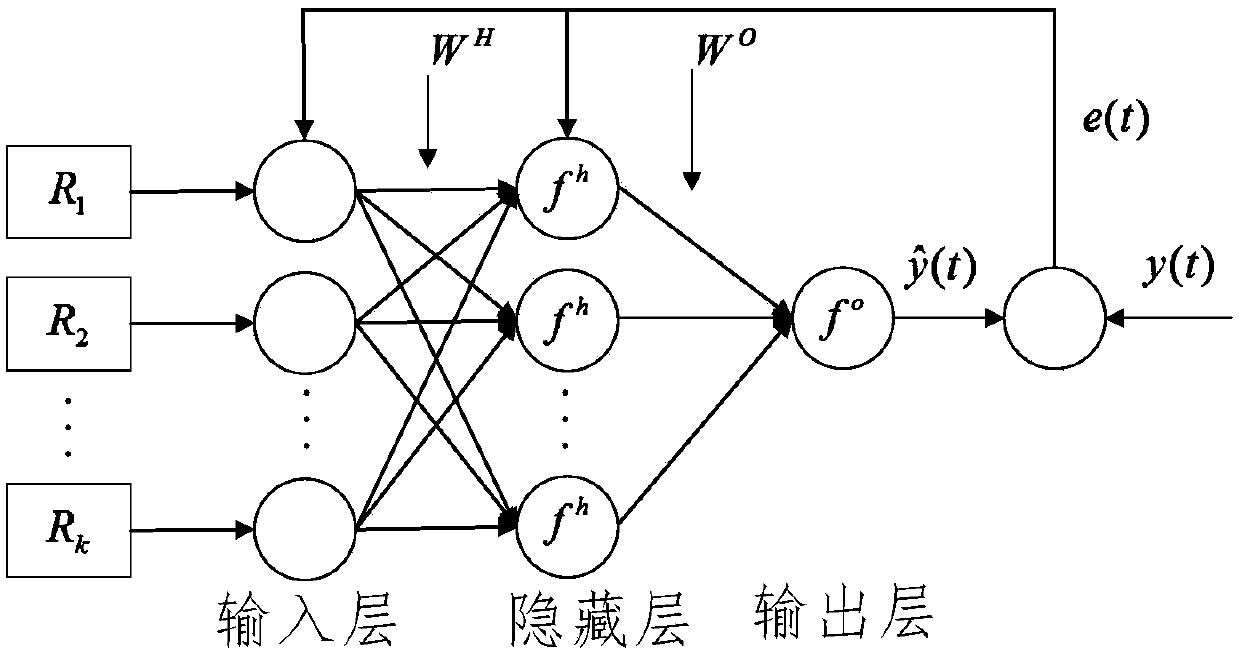
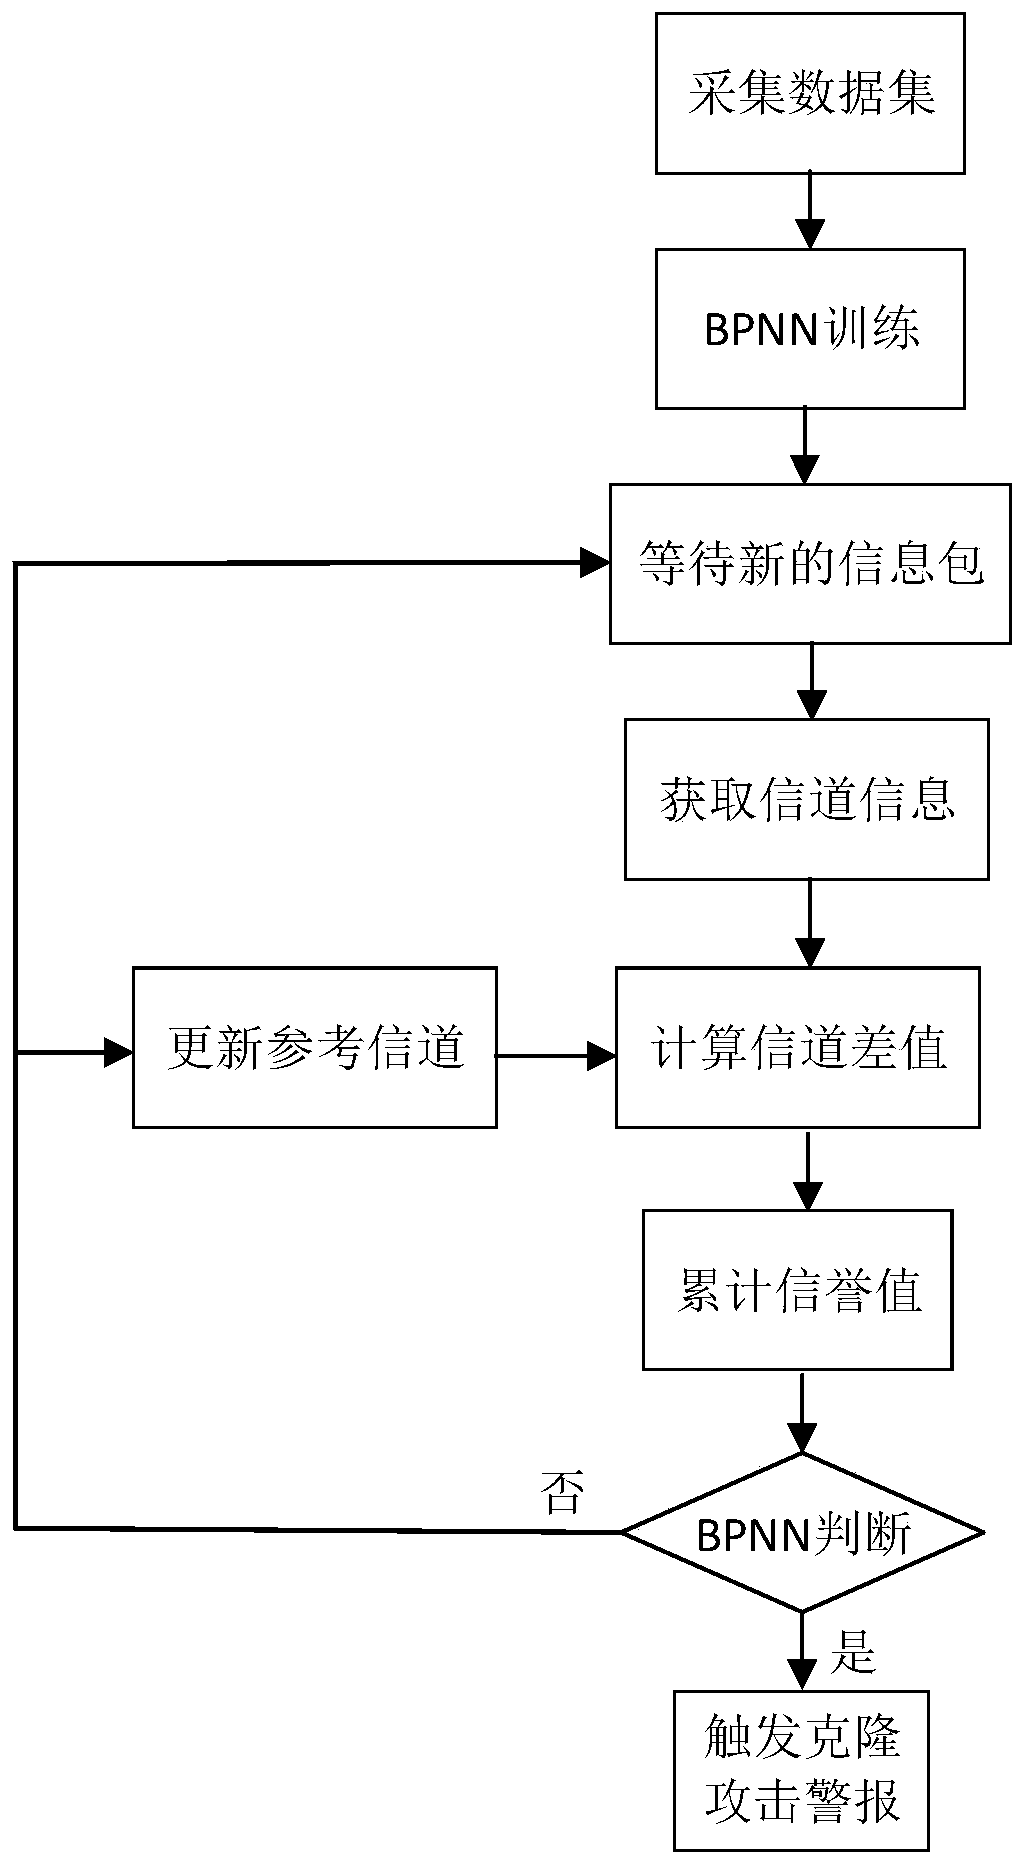
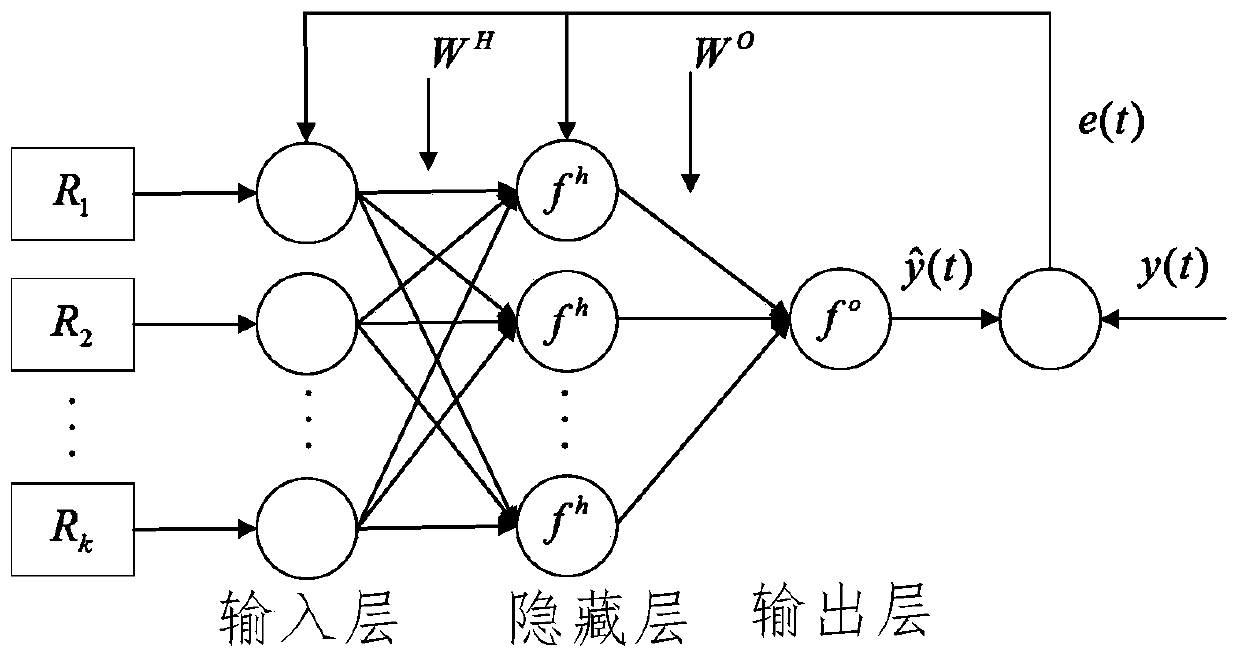
The invention discloses an integrated detection method of an edge side cloned node based on a counterpropagation neural network. The method comprises the following steps: S1. collecting, by an edge side computing node, a data set; S2. training and testing a BPNN by using the data set; S3. waiting for a new information packet; S4. extracting channel information from the information packet, storingreference channel information, and calculating a channel difference value; S5. accumulating the credibility of each node; S6. inputting the credibility of each node into the BPNN to judge whether a clone attack exists; and S7. if no clone attack exists, updating the reference channel information, and if the clone attack exists, sending a clone attack alarm. According to the integrated detection method disclosed by the invention, integrated detection is performed on a data source node on the edge side node by using the BPNN, meanwhile whether the clone attack exists in multiple nodes, thus improving the detection efficiency of the cloned node and reducing the network transmission load and the load of a central network. According to the integrated detection method disclosed by the invention,the influence of random noise of a channel is also reduced by accumulating the credibility and classifying the BPNN, and the accuracy of the detection of the cloned node is improved.
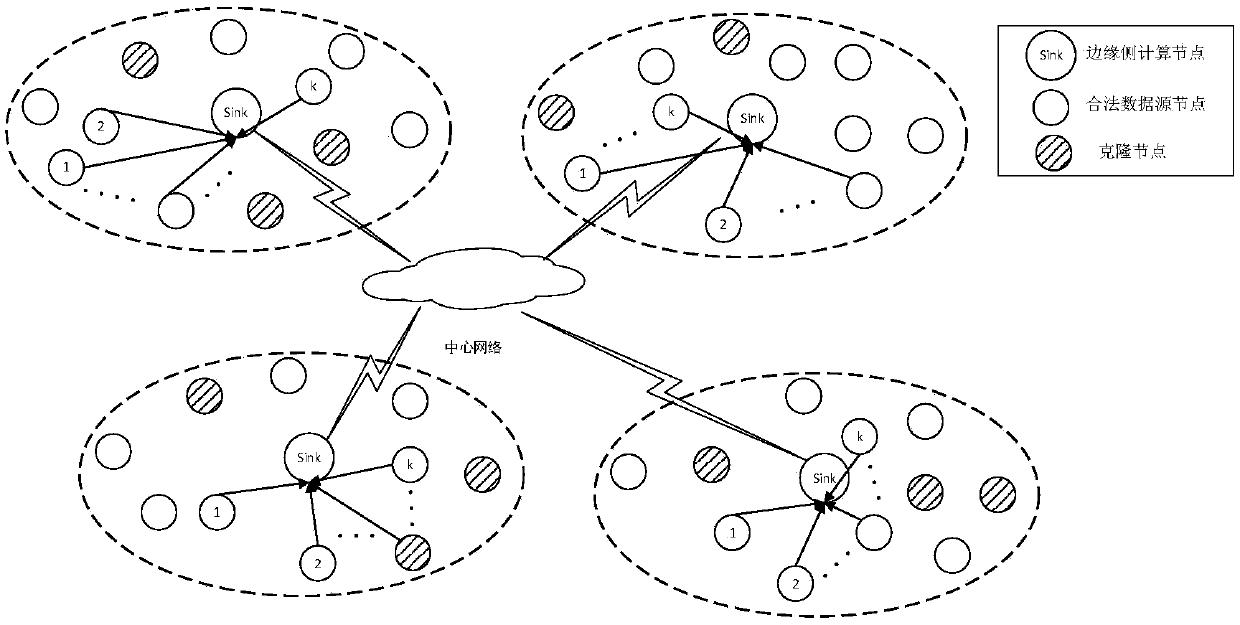
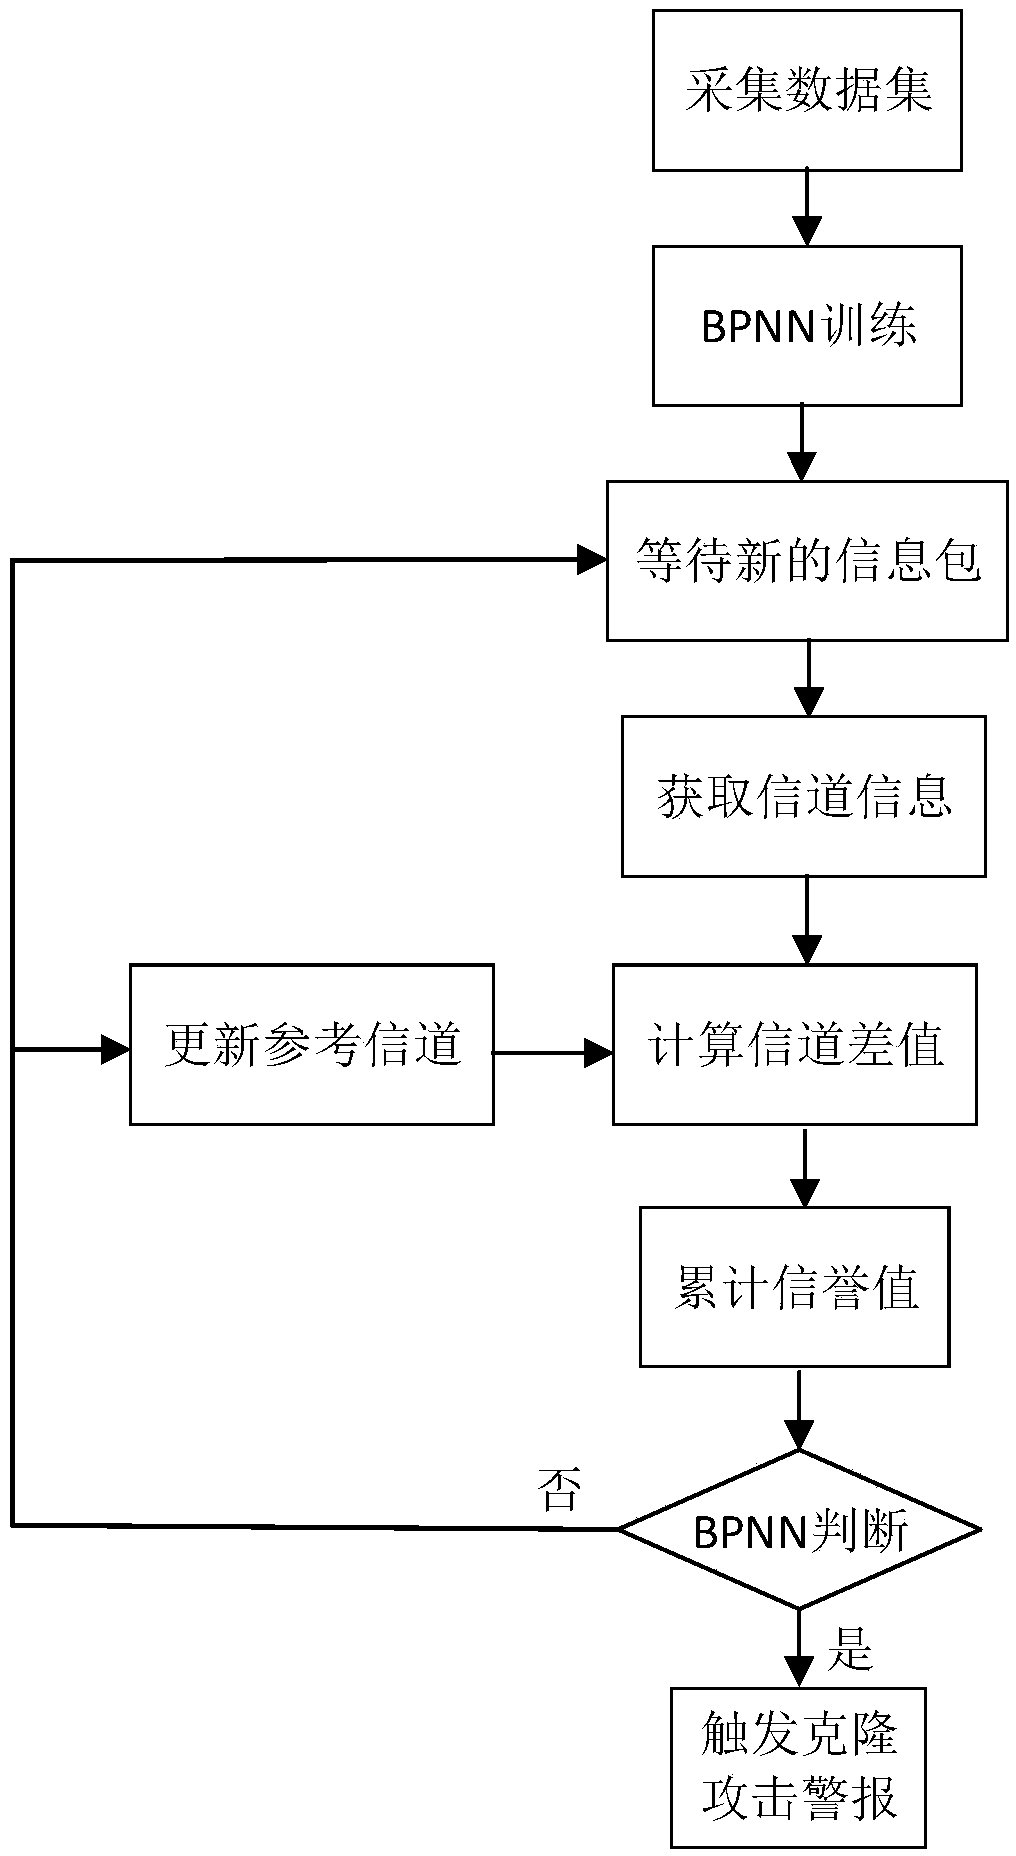
Owner:UNIV OF ELECTRONIC SCI & TECH OF CHINA
Industrial robot real-time fault detection method and system
InactiveCN119141595AEnable real-time fault detectionreduce overheadProgramme-controlled manipulatorAlgorithmCovariance matrix
The invention discloses a real-time fault detection method and system for an industrial robot, and the method comprises the steps: obtaining state data of the industrial robot in previous normal work, and calculating an average value [mu] and a covariance matrix [sigma] of the state data; the method comprises the following steps: acquiring state data of an operating industrial robot in real time every s seconds, taking W seconds as an acquisition period, and acquiring W / s times in the acquisition period; calculating a density estimation value of each piece of state data in the current acquisition period through multivariate Gaussian distribution obeying an average value mu and a covariance matrix sigma; and finally, according to the density estimation value of each piece of state data in the current acquisition period, judging whether the current industrial robot breaks down or not. According to the method, real-time fault detection of the industrial robot is realized, the computing resource overhead is low, high-accuracy fault detection can be realized without huge deep learning model training, and the probability of occurrence of false alarms can be reduced by using an acquisition period.

Owner:JIANGSU SUYIMENG INTELLIGENT TECH CO LTD
Synchronous signal sending and receiving method and device, transmission system
ActiveCN107634924BSolve problems that are too complexReduce Detection ComplexitySynchronisation arrangementTransmission monitoringCarrier signalTransmission system
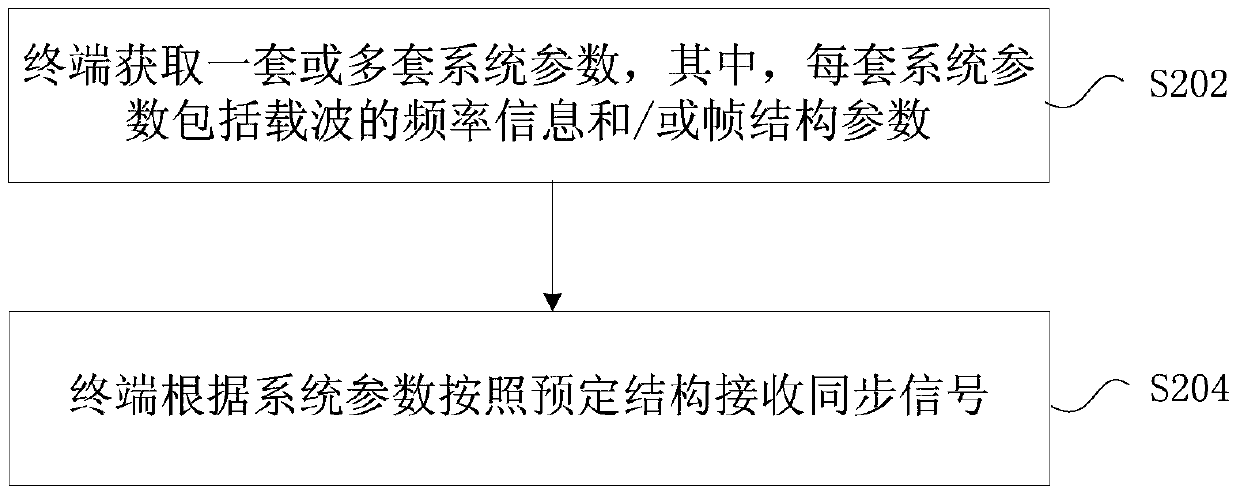
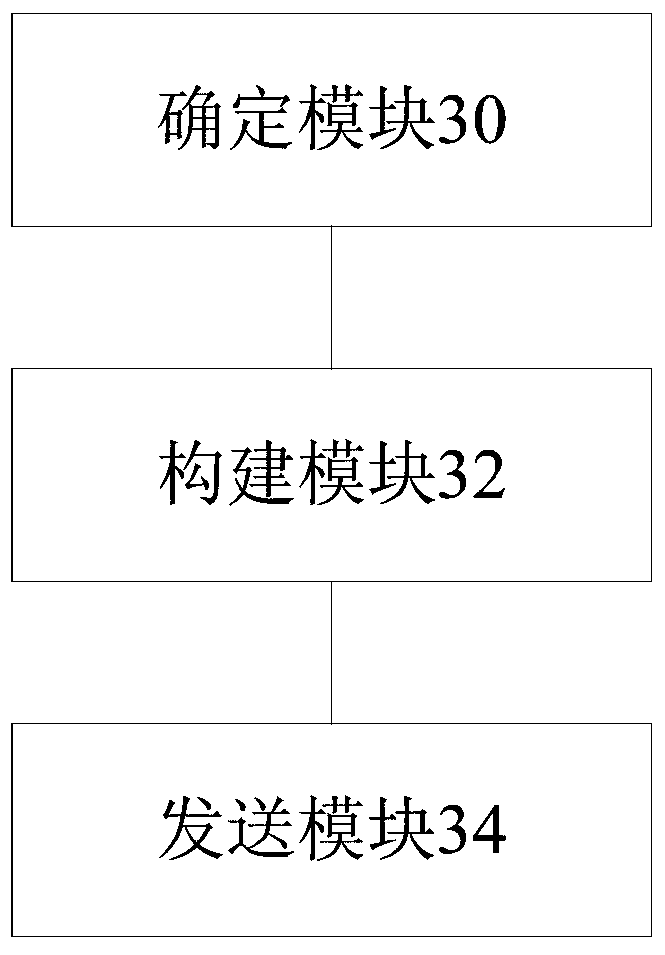
The present invention provides a method and device for sending and receiving synchronization signals, and a transmission system, wherein the method includes: the base station determines one or more sets of system parameters, wherein each set of system parameters includes frequency information of the carrier frequency and / or The frame structure parameters of the carrier frequency; the base station constructs a synchronization signal of a predetermined structure according to the system parameters; the base station sends the synchronization signal to the terminal; wherein, one or more sets of system parameters correspond to the same predetermined structure. The present invention solves the problem of excessive complexity in detecting synchronous signals in the related art.
Owner:ZTE CORP
Robot collision detection method based on second-order generalized momentum observer
ActiveCN113459160AAdd adjustable parametersImprove controllabilityManipulatorCollision detectionComputational physics
The invention discloses a robot collision detection method based on a second-order generalized momentum observer. The method comprises the following steps: firstly, constructing a robot kinetic model, and recognizing kinetic parameters; secondly, establishing a generalized momentum observer, determining a gain coefficient, establishing a friction model in a targeted manner, and identifying model parameters; and thirdly, a second-order generalized momentum observer is established through a second-order damping model, a PD regulator is connected in series on the basis of the second-order damping model, and a threshold value is set. According to the robot collision detection method based on the second-order generalized momentum observer, adjustable parameters are increased, system controllability is improved, short transition time is easier to obtain, system collision detection delay is reduced, and the application value is high. The method can be applied to the collision detection technology.


Owner:FOSHAN INST OF INTELLIGENT EQUIP TECH
Face feature detection method and device, medium and electronic equipment
PendingCN113011356AEasy to detectGuaranteed detection accuracyCharacter and pattern recognitionNeural architecturesFeature extractionEngineering
The embodiment of the invention provides a face feature detection method and device, a medium and electronic equipment, and relates to the technical field of artificial intelligence. The method comprises the following steps: acquiring a to-be-detected image; inputting the to-be-detected image into a human face feature detection model, and outputting human face region coordinates and human face key point coordinates corresponding to the to-be-detected image, wherein the human face feature detection model comprises a target human face region detection network and a human face key point detection network; and marking the to-be-detected image through the human face region coordinates and the human face key point coordinates, and generating the to-be-detected image marked with the human face region and the human face key points. According to the technical scheme of the embodiment of the invention, the face region coordinates and the face key point coordinates can be output at the same time, the image containing the face region labels and the face key point labels can be quickly obtained, and the face feature extraction efficiency is effectively improved.


Owner:杭州网易智企科技有限公司
Deep learning-based point-by-point classification fault detection method
ActiveCN113537360AEasy to detectReduce detection delayCharacter and pattern recognitionNeural architecturesData setIndustrial systems
The invention discloses a deep learning-based point-by-point classification fault detection method (DPCFD), and the method specifically comprises the steps: collecting the data of each channel of an industrial system, and obtaining an original data sequence; inputting the original data sequence into a pre-trained sequence state generator model to generate a real-time state sequence of each channel; splicing the real-time state sequence of each channel and the original data sequence according to the time dimension to obtain a fused data sequence, grouping the channels according to the incidence relation between the channels, and inputting the fused data sequence into a pre-trained fault detection model based on deep learning point-by-point classification according to the channel grouping to obtain a sequence of the fault detection results. According to the method, the DPCFD method is evaluated by using a standard data set Tennessee Eschermann, and experimental results show that the method has the advantages of high detection performance and low detection time delay.


Owner:NAT UNIV OF DEFENSE TECH
Method for improving uplink synchronization detection efficiency in time division synchronous code division multi-address system
InactiveCN101267245AImprove detection efficiencyReduce detection delayRadio transmission for post communicationTime delaysSynchronous detection
The present invention discloses a method for increasing the detecting efficiency of the ascending synchronous code in a time division synchronization code division multiple access system. The high layer of the network allocates an access service grade and synchronous code and the corresponding information of the ascending pilot channel UpPCH sub-channel to the terminal when the small area is accidentally accessed. The node B is allocated with an ascending pilot channel UpPCH sub-channel and a corresponding synchronous information. The terminal transmits the corresponding ascending synchronous code on the sub-channel corresponding with the access service grade itself and initializes an ascending synchronization process to a node B. The node B confirms an UpPCH sub-channel number according to the system sub-frame number and only detects the ascending synchronous code which is allowed to be transmitted in the UpPCH sub-channel in an ascending pilot frequency time slot of a sub-frame. The invention leads to that the NodeB assures the number of the synchronous code to be detected and the specific synchronous code sequence through improving the allocation of the high layer. The probability of time delay of detection and error judgment is reduced, and the detecting efficiency is improved.


Owner:ZTE CORP
5G uplink physical layer channel processing method, device, equipment and product
ActiveCN114039713ASave storage spaceSimplify complexityMulti-frequency code systemsPilot signal allocationTime domainTelecommunications
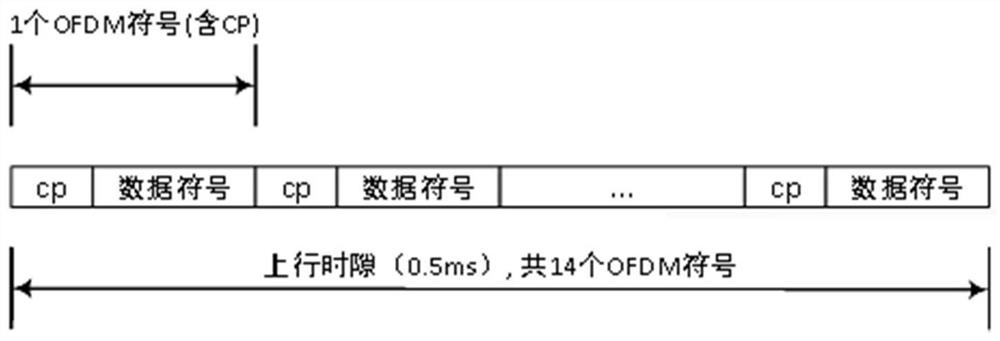
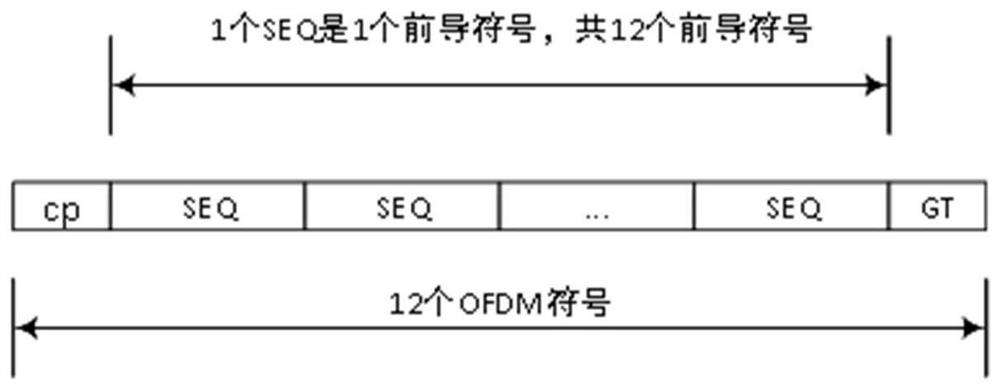
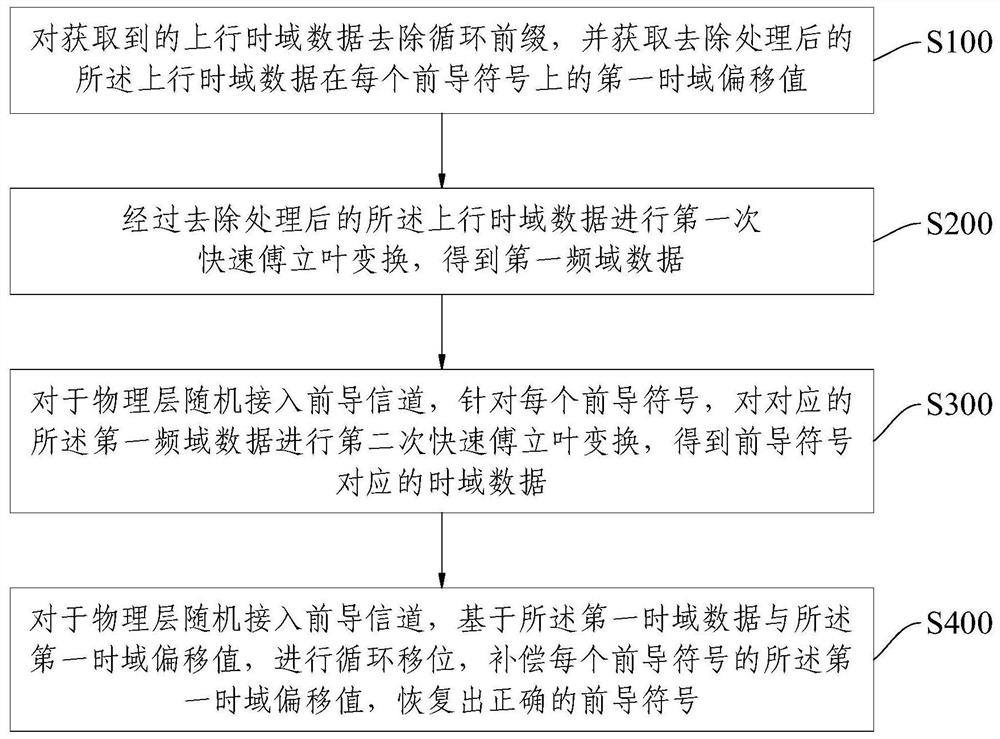
The present invention provides a 5G uplink physical layer channel processing method, device, equipment and product, and relates to the technical field of communications. The method comprises the following steps: removing a cyclic prefix from acquired uplink time domain data, and acquiring a first time domain offset value of the uplink time domain data after removal processing on each preamble symbol; performing first fast Fourier transform on the uplink time domain data subjected to removal processing to obtain first frequency domain data; performing second fast Fourier transform on the corresponding first frequency domain data to obtain time domain data corresponding to the preamble symbol; and performing cyclic shift based on the first time domain data and the first time domain offset value, compensating the first time domain offset value of each preamble symbol, and recovering a correct preamble symbol. According to the invention, the detection time delay of the PRACH channel is reduced, the detection efficiency is improved, and the correctness of PRACH detection is ensured, so that the user perception is improved.
Owner:INSPUR SOFTWARE TECH CO LTD
Fault Diagnosis and Isolation Method of SINS / Multi-LDV Integrated Navigation System
ActiveCN119147013BImprove speed measurement accuracyquick responseNavigation by speed/acceleration measurementsDevices using optical means
The present invention discloses a fault diagnosis and isolation method for a SINS / multi-LDV combined navigation system, comprising the following steps: constructing a Kalman filter system for combined navigation; when the speed meter measurement data of a new moment arrives, calculating the statistics for fault diagnosis between two sets of speed meters; determining whether the speed meter fails according to the statistics and the confidence threshold and according to the threshold voting rule, and locating the speed meter with the failure when the failure exists; eliminating the measurement data of the speed meter with the failure, and using the remaining measurement data to perform Kalman filter measurement update. The present invention is applied to the fields of combined navigation and fault detection technology, effectively overcoming the defects and shortcomings of the traditional fault detection algorithm that cannot effectively take into account both hard faults and soft faults, improving the reliability and robustness of the SINS / LDV combined navigation system, and having high application value and promotion potential.

Owner:NAT UNIV OF DEFENSE TECH
Method and device for detecting physical broadcast channel
ActiveCN102076018BReduce detection delayNetwork traffic/resource managementAssess restrictionBroadcast channelsTelecommunications


Owner:SHANGHAI HUAWEI TECH CO LTD
Satellite signal ground interference detection method and device
PendingCN121770649AEnsure feasibilityEnsure efficiencyTransmission monitoringRadio transmissionInterference (communication)Time delays
The invention provides a satellite signal ground interference detection method and device, and solves the problem that low-delay detection cannot be carried out on transient interference due to the fact that a traditional interference suppression method in satellite-ground direct communication depends on complex channel estimation. The satellite signal ground interference detection method comprises the following steps: receiving a communication signal; determining a detection statistic according to the communication signal; and performing recursive accumulation on the detection statistics to generate an accumulated decision amount, and determining whether the transient interference occurs based on the accumulated decision amount. According to the invention, interference detection is converted into statistical distribution change detection, a traditional channel estimation process is avoided, and millisecond-level quick response is realized; a CUSUM detector and a GLR detector are suitable for scenes with known interference directions and scenes with unknown interference directions respectively, so that the false alarm rate is reduced while low detection time delay is ensured; and the adopted window limiting mechanism ensures the feasibility of the method on the resource-limited terminal.

Owner:CHINA ACADEMY OF INFORMATION & COMM
An integrated detection method for edge side clone nodes based on backpropagation neural network
ActiveCN108924150BAccurate judgmentImprove response efficiencyTransmissionPattern recognitionData set
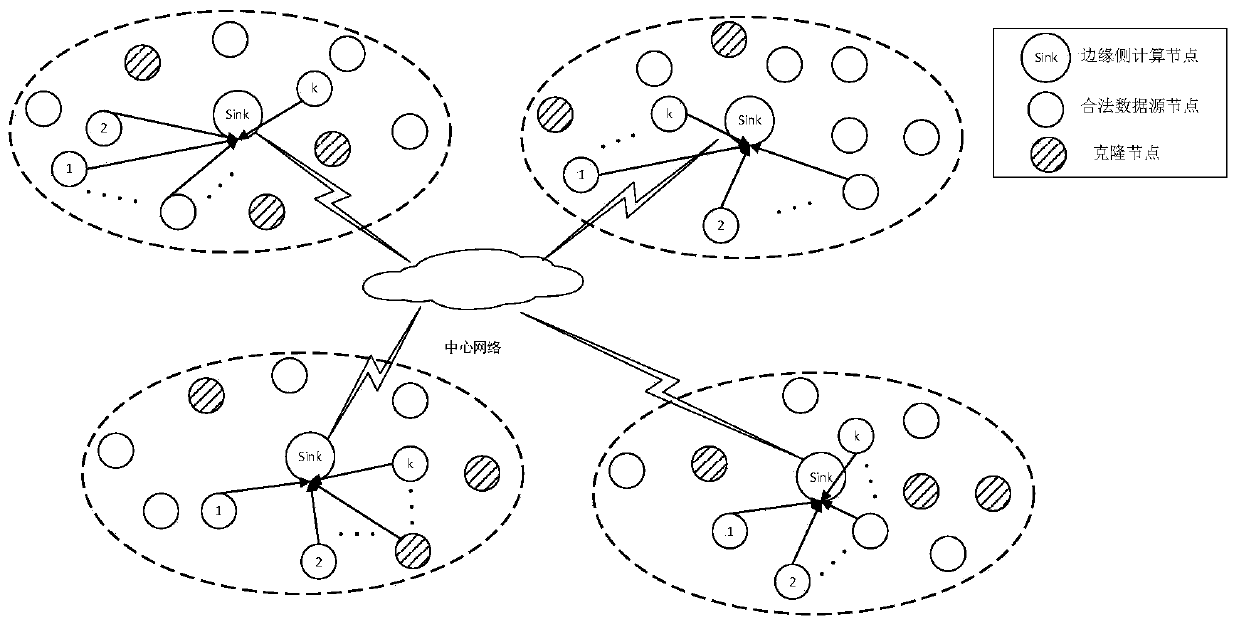
The invention discloses an integrated detection method of edge side clone nodes based on backpropagation neural network, comprising the following steps: S1. Edge side computing nodes collect data sets; S2. Use the data sets to train and test BPNN; S3. Wait New information packet; S4. Extract channel information from the information packet, store reference channel information, and calculate channel difference; S5. Accumulate the reputation of each node; S6. Input the reputation of each node into BPNN to determine whether there is a clone attack; S7 . If there is no cloning attack, update the reference channel information, and if there is a cloning attack, send a cloning attack alarm. The invention utilizes BPNN at the edge side nodes to perform integrated detection on the data source nodes, and simultaneously judges whether there is a clone attack in multiple nodes, improves the detection efficiency of the clone nodes, and reduces the network transmission load and the central network load. The present invention also reduces the influence of channel random noise and improves the accuracy of clone node detection by accumulating reputation and BPNN classification.
Owner:UNIV OF ELECTRONICS SCI & TECH OF CHINA
DDOS attack detection method based on software defined network
ActiveCN112953910BSolve the problem of missed detection of DDoS attacksImprove detection accuracySecuring communicationStreaming dataData pack
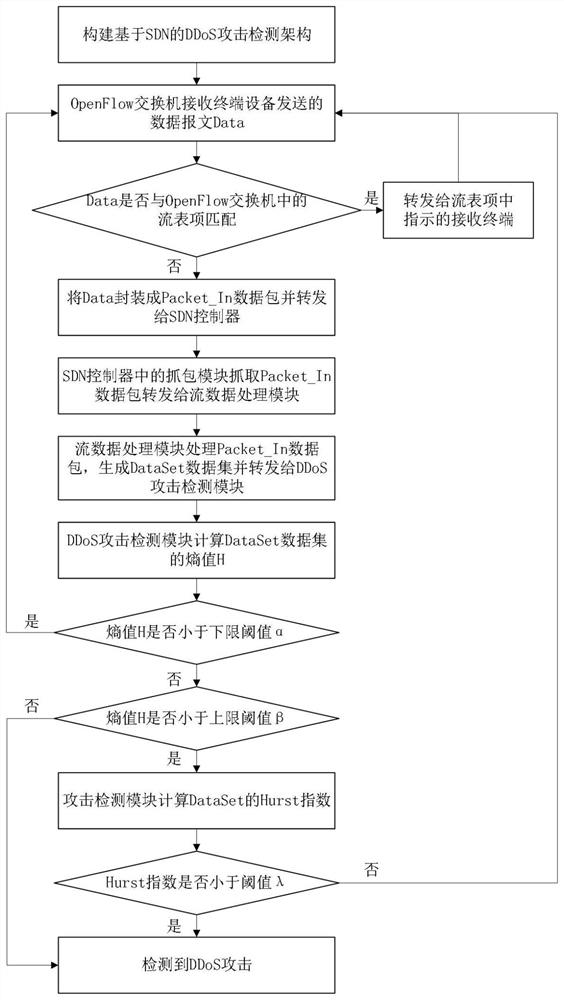
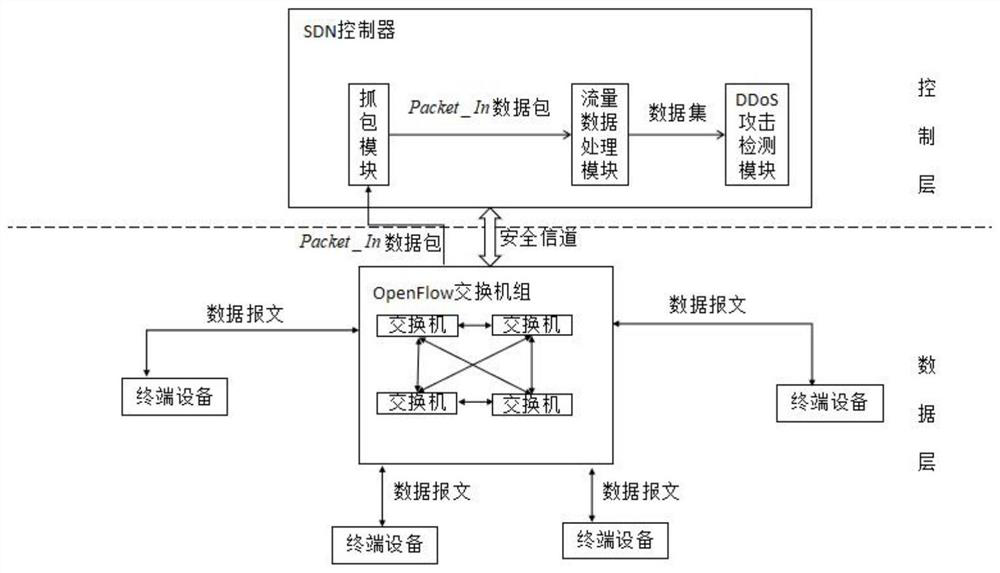
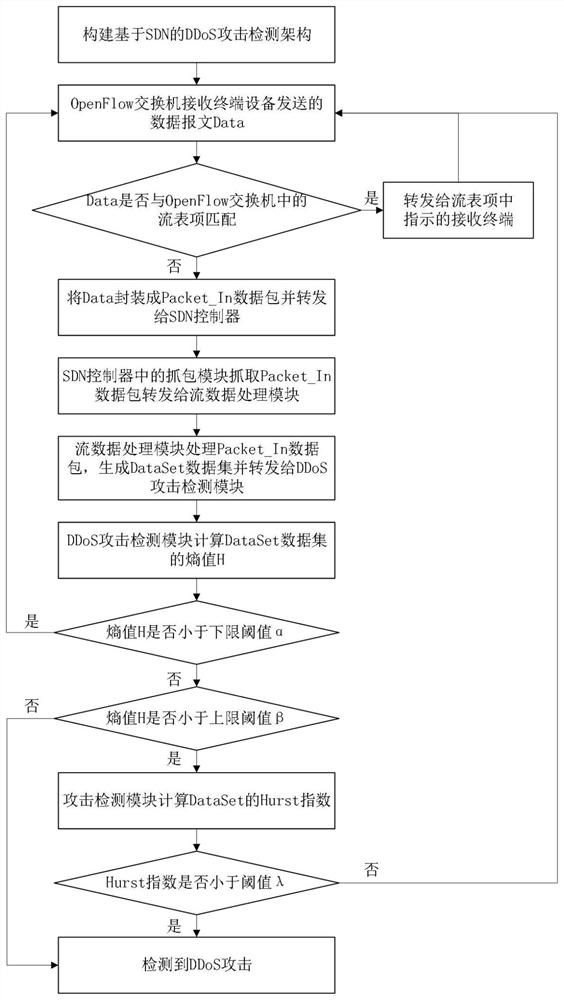
The invention proposes a DDoS attack detection method based on a software-defined network, which is used to solve the technical problems of low accuracy and high delay when detecting DDoS attacks in an SDN network in the prior art. The implementation steps are: constructing a software-defined network DDoS attack detection architecture of the network, each OpenFlow switch S in the data layer m Receive data packets and forward them, the packet capture module in the SDN controller captures data packets and forwards them, the stream data processing module in the SDN controller obtains stream data sets, and the DDoS attack detection module in the SDN controller obtains DDoS attack detection result. The software-defined network-based DDoS attack detection framework and DDoS attack detection module adopted by the present invention detect DDoS attacks by combining entropy and network self-similarity, which can significantly improve the accuracy of DDoS attack detection and reduce time delay.
Owner:XIDIAN UNIV
Method for improving uplink synchronization detection efficiency in time division synchronous code division multi-address system
InactiveCN101267245BImprove detection efficiencyReduce detection delaySynchronisation arrangementTransmissionTime delaysSynchronous detection
The present invention discloses a method for increasing the detecting efficiency of the ascending synchronous code in a time division synchronization code division multiple access system. The high layer of the network allocates an access service grade and synchronous code and the corresponding information of the ascending pilot channel UpPCH sub-channel to the terminal when the small area is accidentally accessed. The node B is allocated with an ascending pilot channel UpPCH sub-channel and a corresponding synchronous information. The terminal transmits the corresponding ascending synchronouscode on the sub-channel corresponding with the access service grade itself and initializes an ascending synchronization process to a node B. The node B confirms an UpPCH sub-channel number according to the system sub-frame number and only detects the ascending synchronous code which is allowed to be transmitted in the UpPCH sub-channel in an ascending pilot frequency time slot of a sub-frame. Theinvention leads to that the NodeB assures the number of the synchronous code to be detected and the specific synchronous code sequence through improving the allocation of the high layer. The probability of time delay of detection and error judgment is reduced, and the detecting efficiency is improved.


Owner:ZTE CORP
A method for detecting information and user equipment
ActiveCN104885496BReduce detection delayReduce power consumptionPower managementAssess restrictionObjective informationUser equipment
Embodiments of the present invention provide an information detection method and user equipment, which relate to the communication field and enable the user equipment to reduce detection delay, power consumption and detection complexity without knowing the channel environment where it is located. The method is as follows: first determine the reference information, then determine the detection level of at least one target information in the main information block, downlink control information, and system information block according to the reference information, and then perform the detection level of the target information according to the detection level of the target information. detection to obtain the target information. Embodiments of the present invention are used for detection of information.


Owner:HUAWEI TECH CO LTD
A Cognitive Radio Spectrum Sensing Method
InactiveCN105763273BQuick checkReduce detection delayTransmission monitoringFrequency spectrumComputer science


Owner:UNIV OF ELECTRONICS SCI & TECH OF CHINA