
Patents
Literature
3946 results about "Data center" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
A data center (American English) or data centre (British English) is a building, dedicated space within a building, or a group of buildings used to house computer systems and associated components, such as telecommunications and storage systems.
Web application internationalization
InactiveUS7784026B1Eliminate needEasy constructionExecution for user interfacesMemory systemsMeta levelWeb page
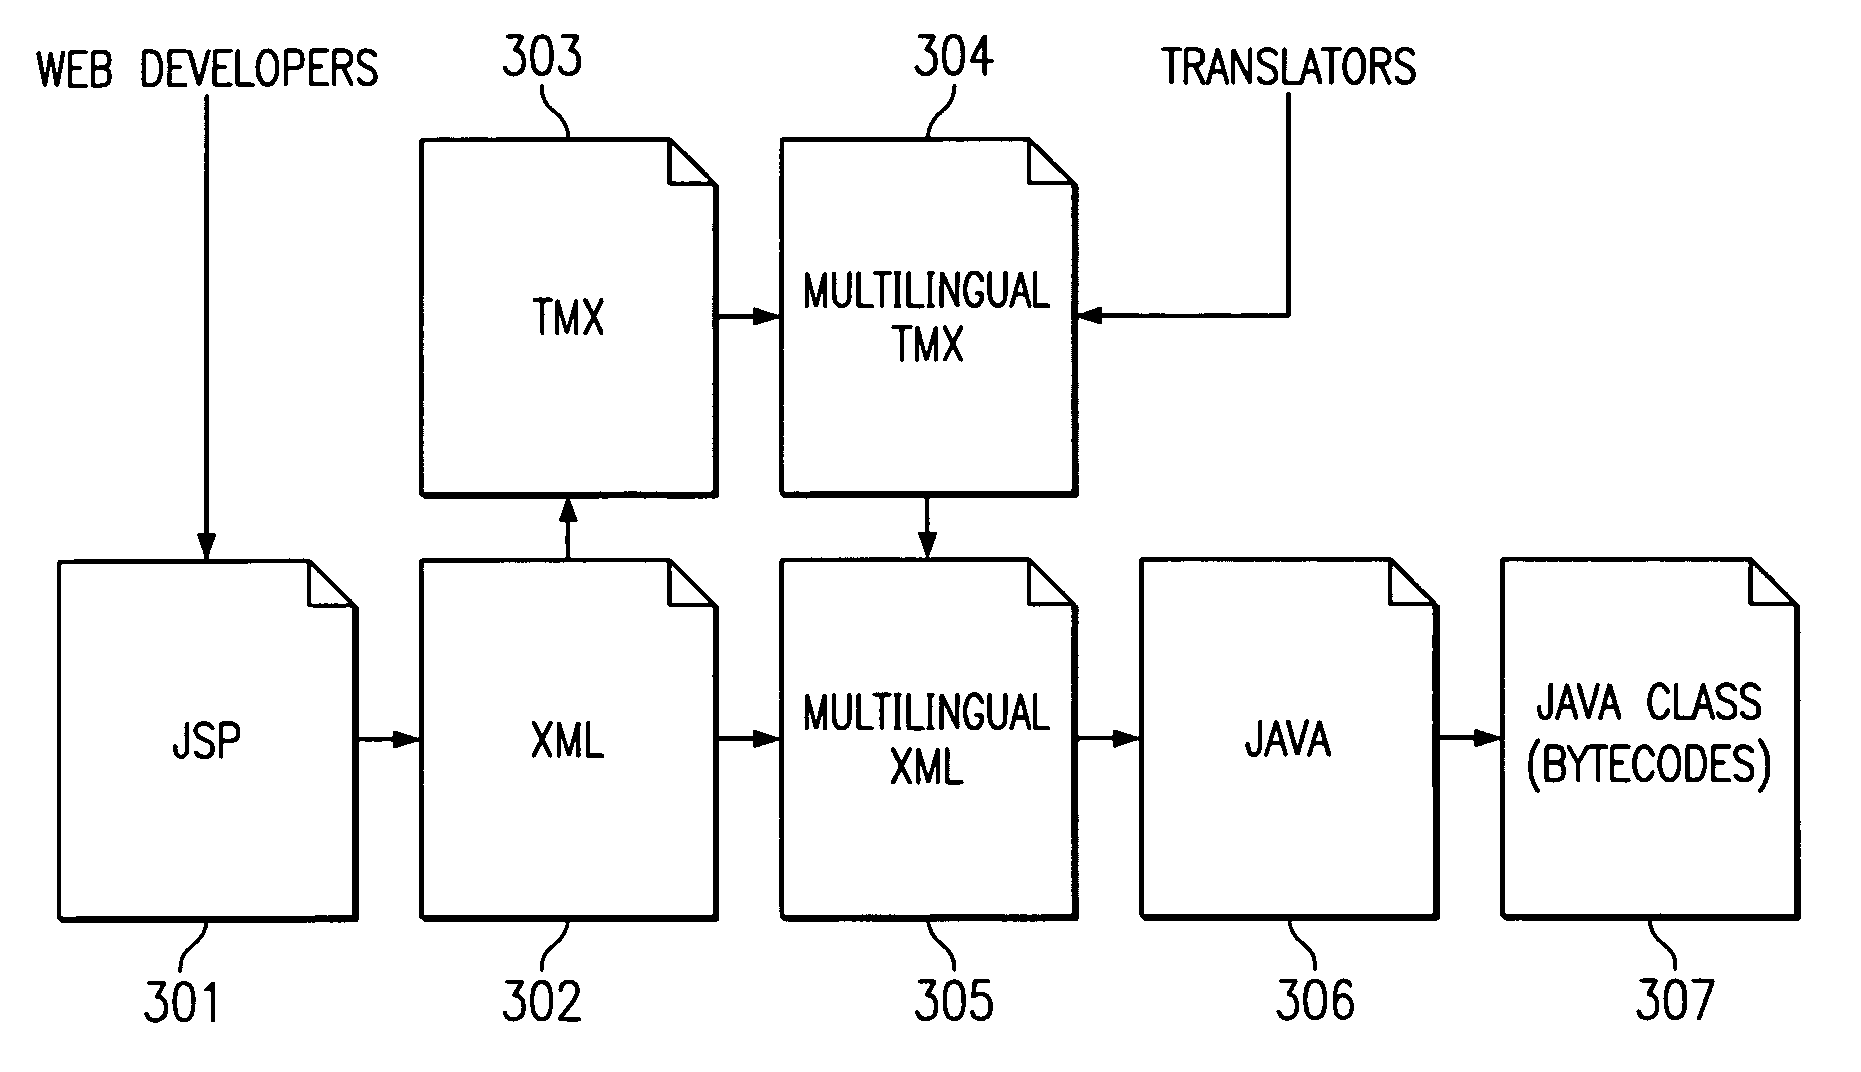
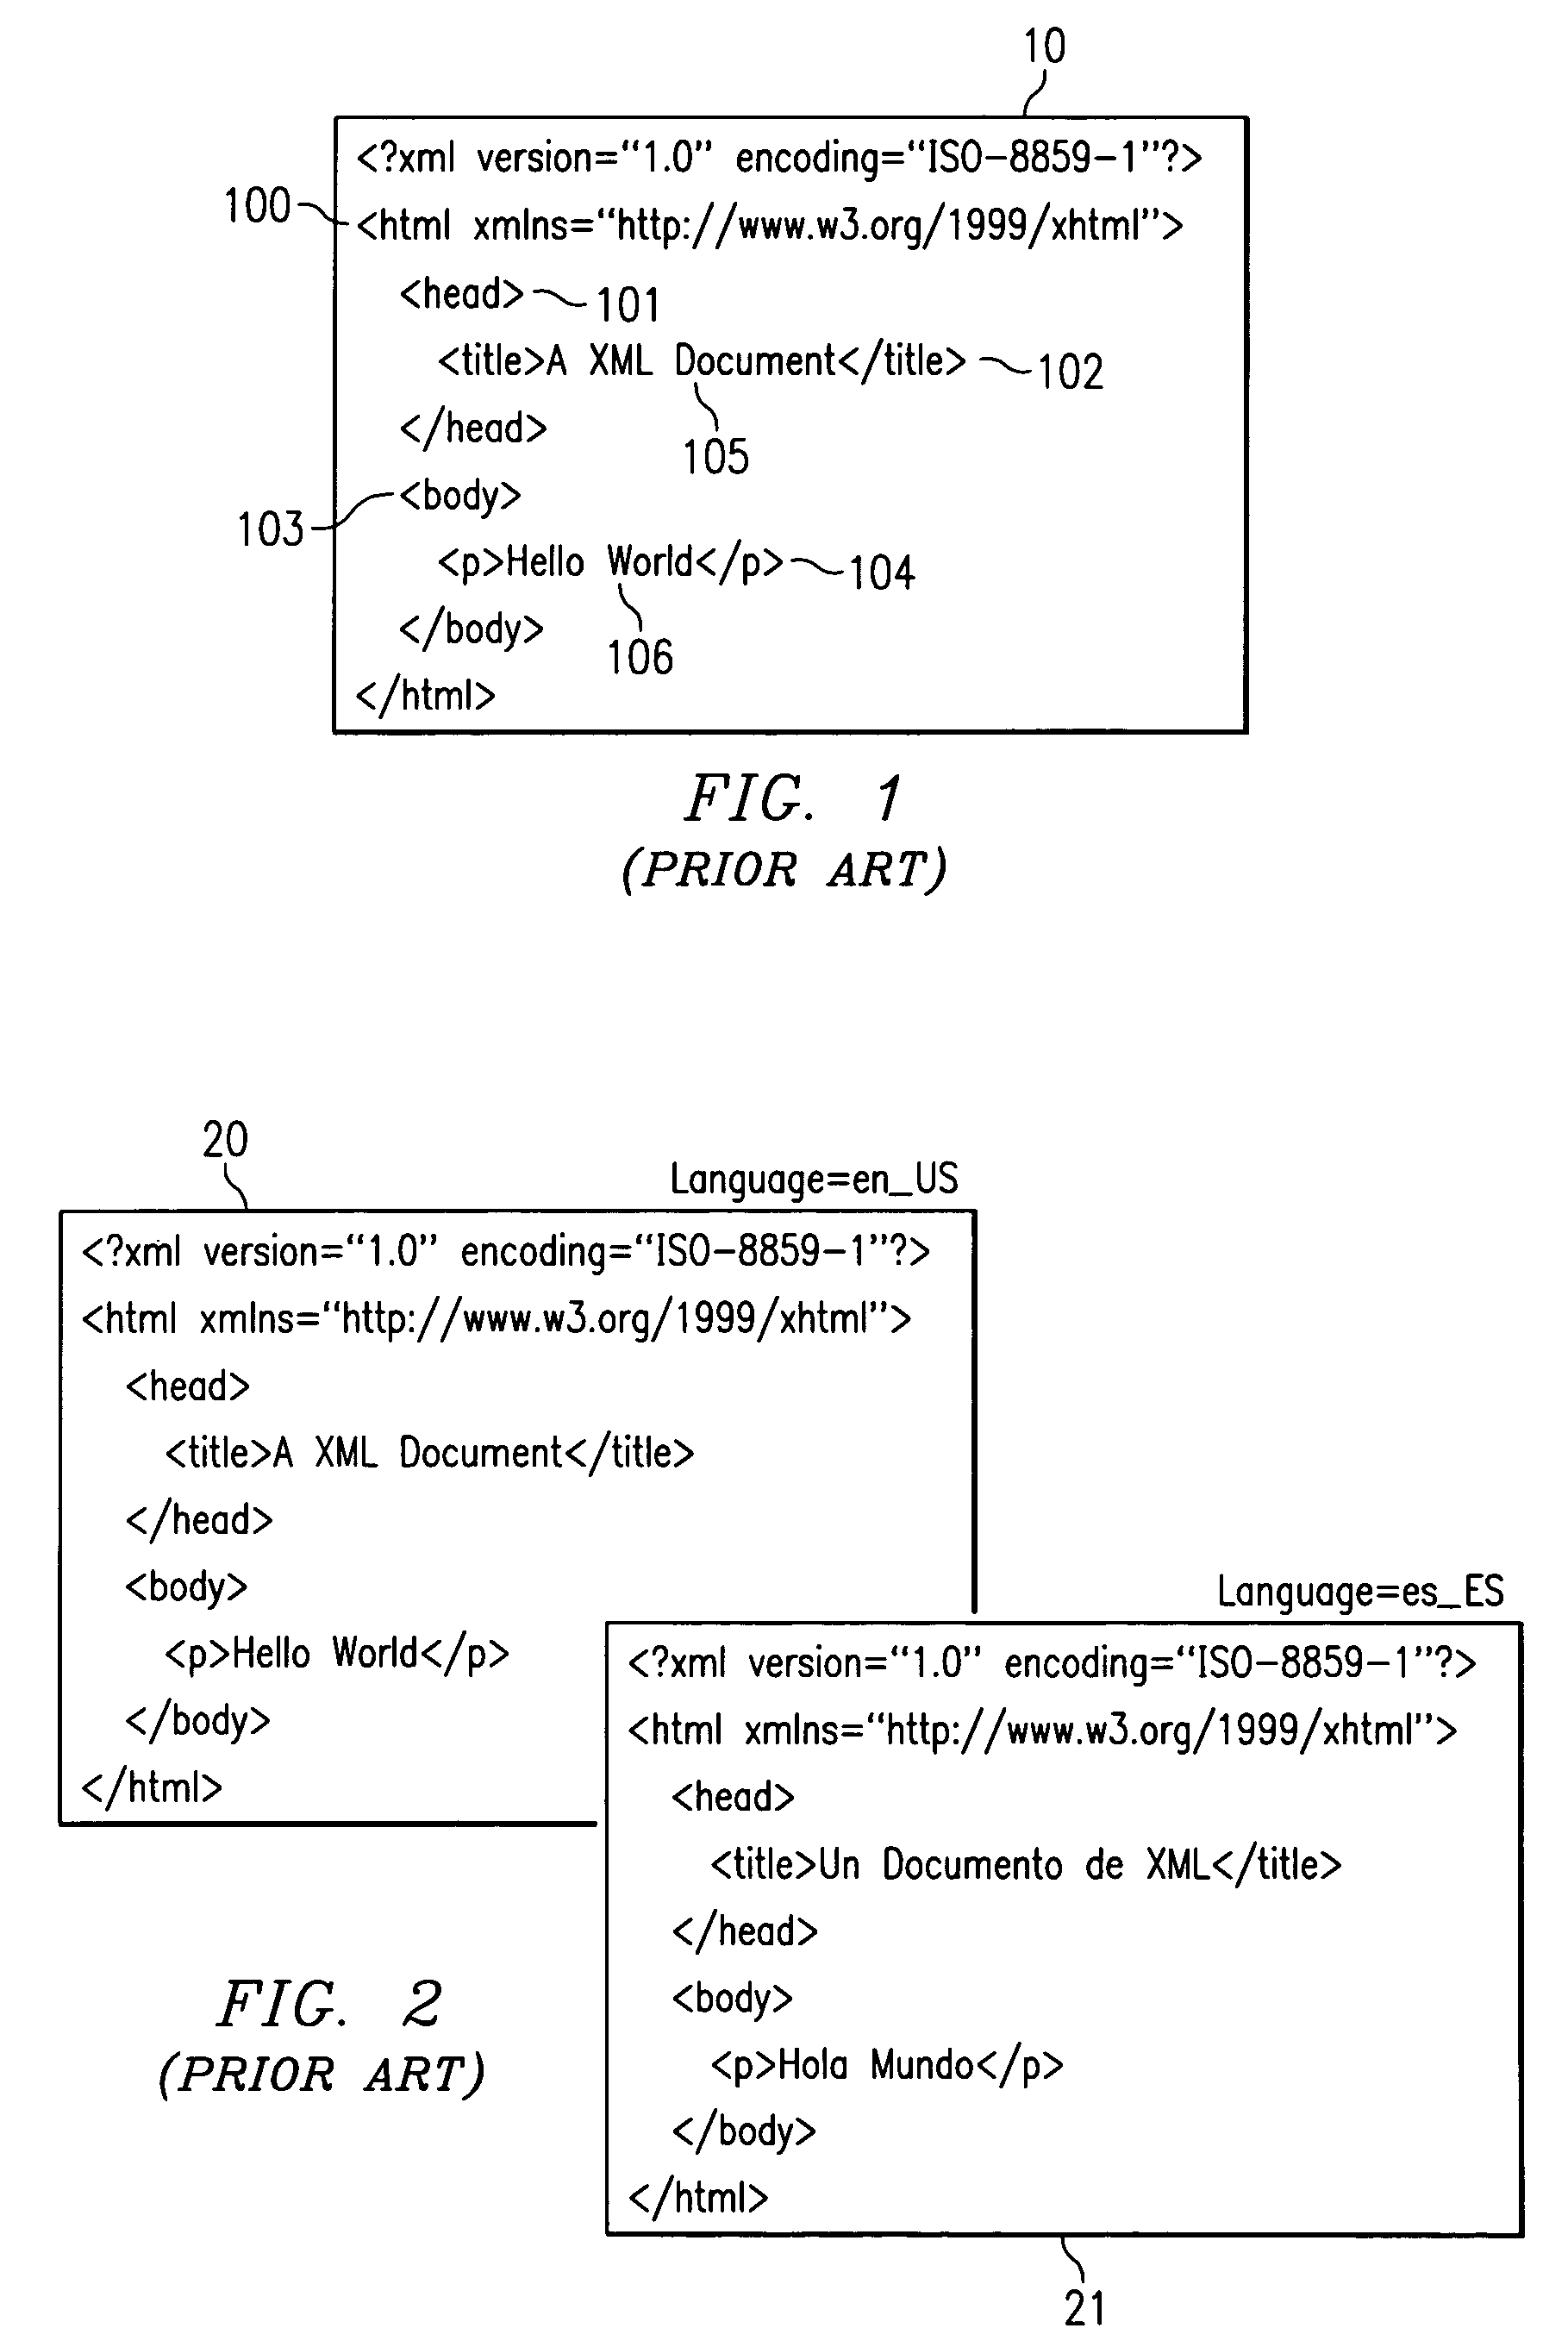
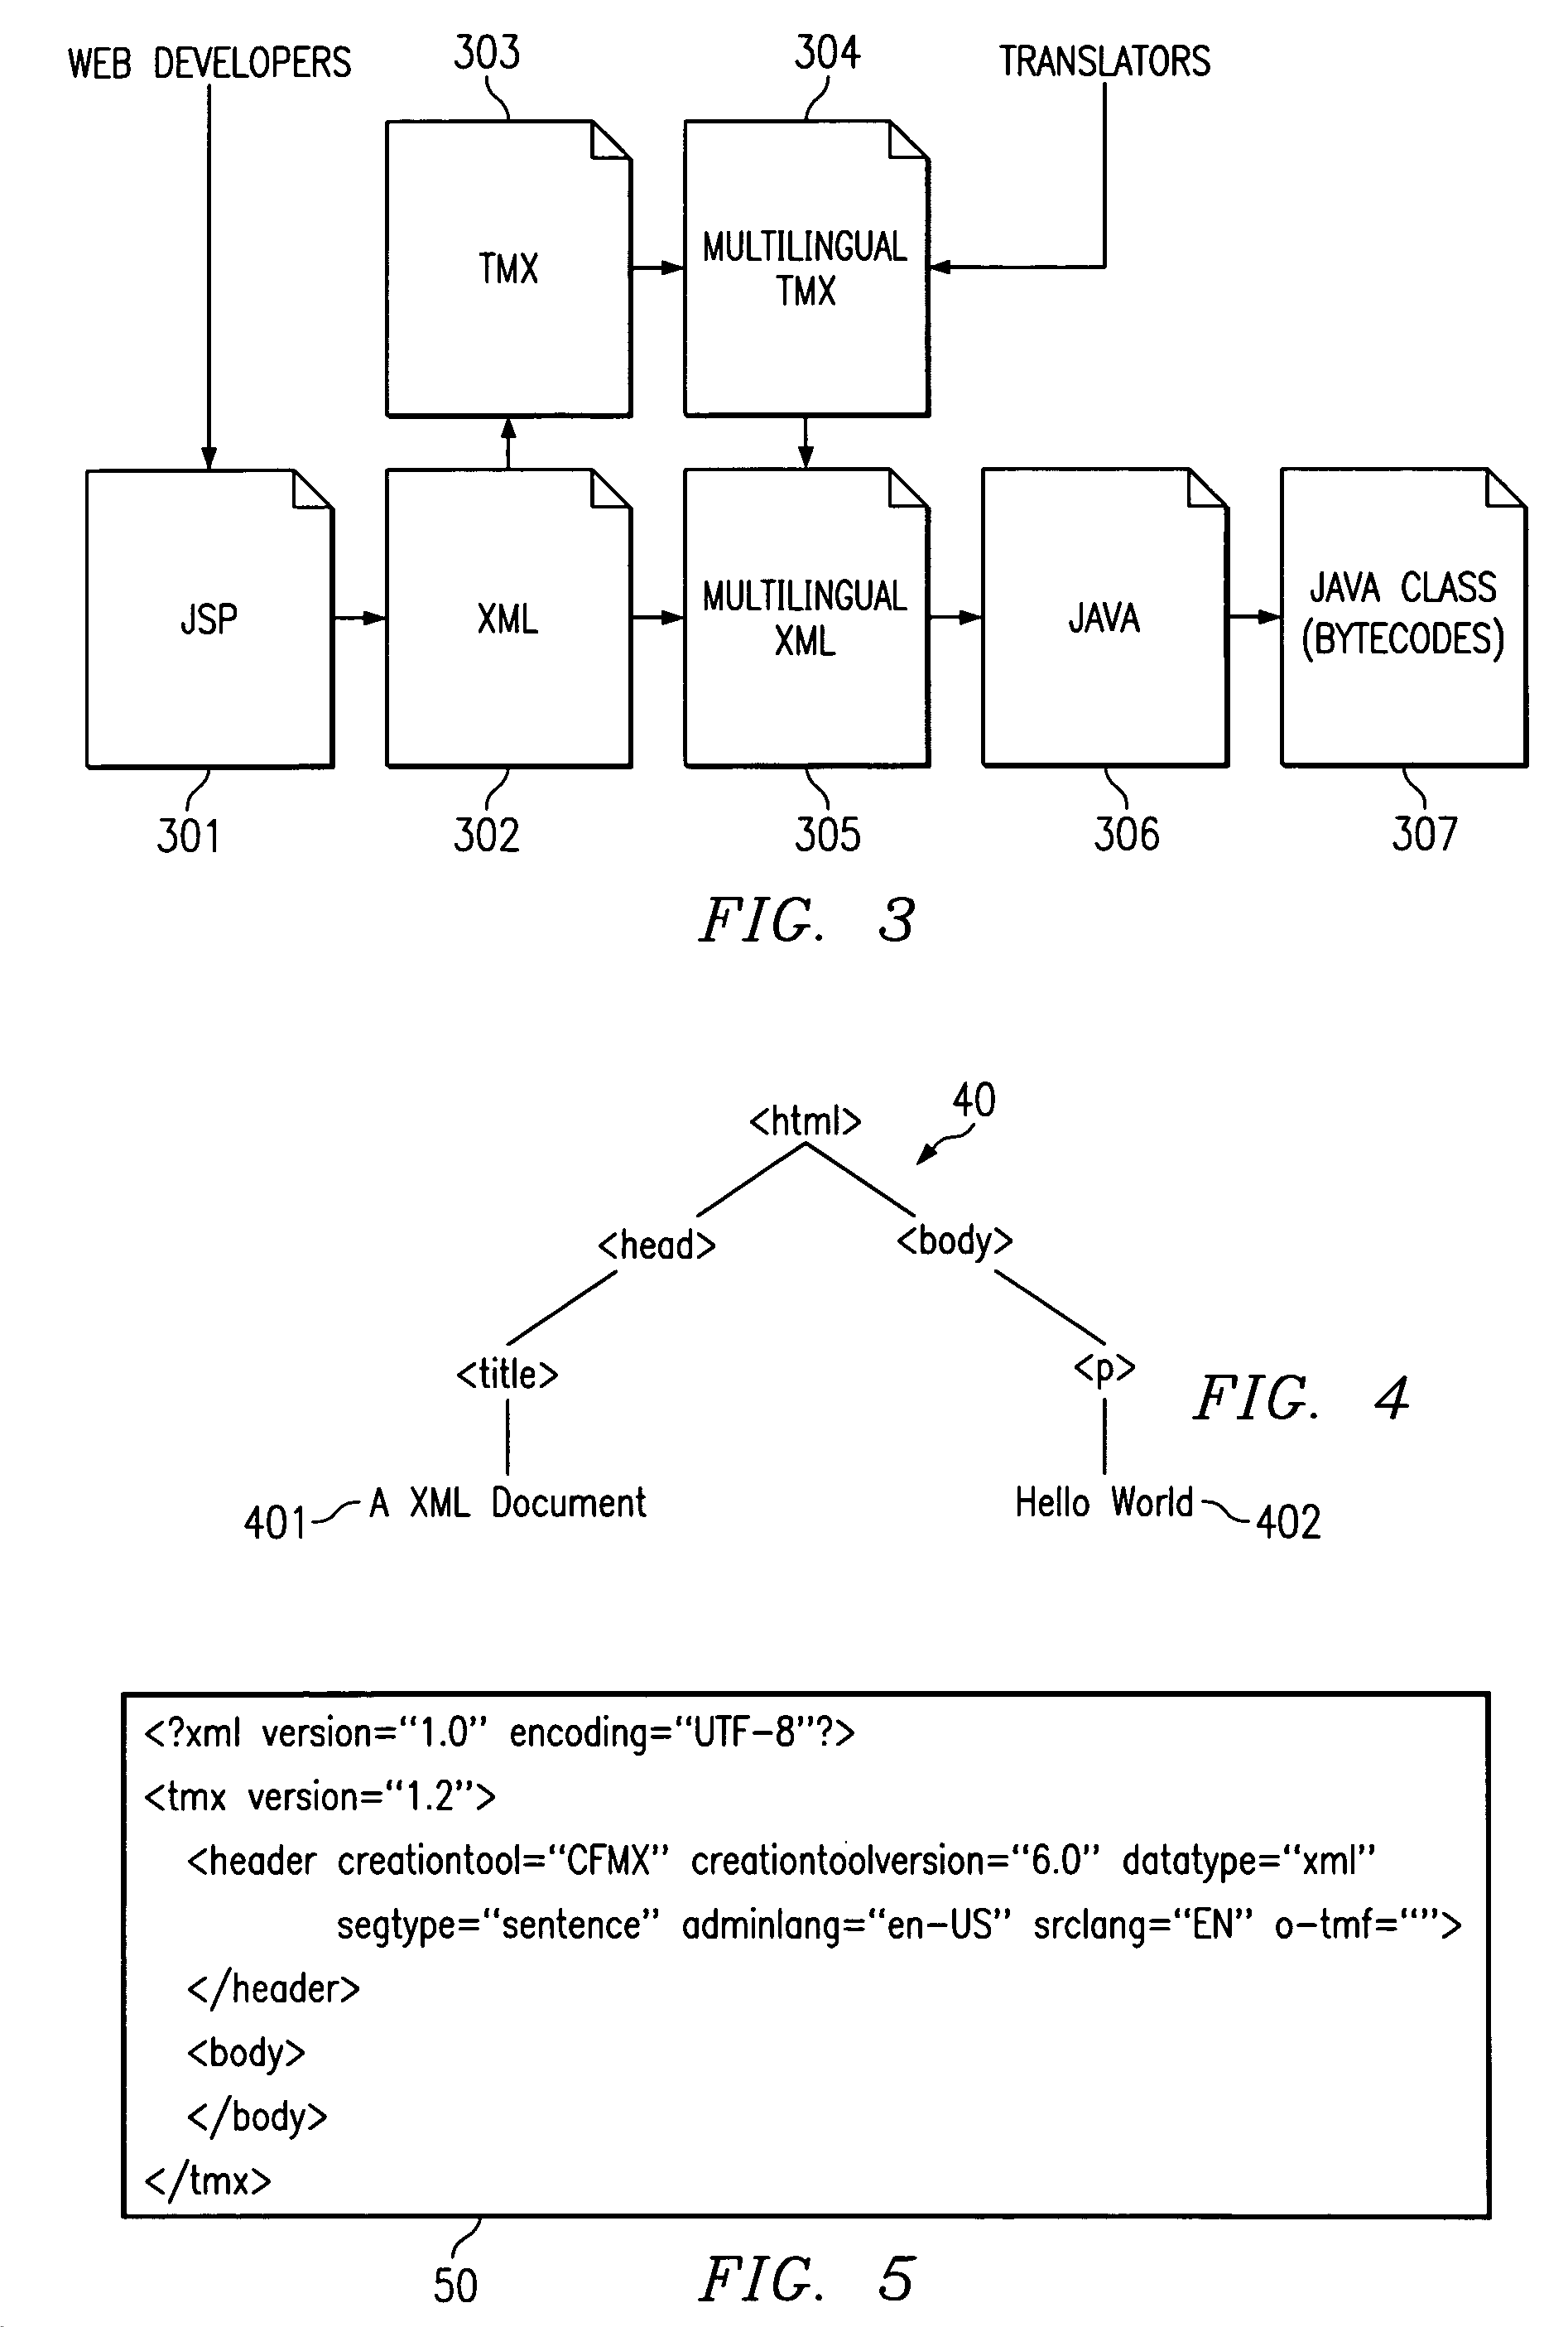
A system and method is described for internationalization of web pages by extracting translatable content from extensible mark-up language (XML), or similar data-centric meta-language representations of web pages or data used to build web pages. The extracted translatable content is stored in a translation task repository (TTR) accessible by the web developer and the translator. The XML representation is then modified to include selection control logic to select the appropriate translations for insertion into the final web page. The translator accesses the TTR to translate the appropriate content and saves the translations back to the TTR associated with the original translatable data. The translations are obtained from the TTR as selection cases for the selection control logic of the XML representation. As the XML is converted into the web source code, the selection logic and translations are embedded therein facilitating building the web site in multiple different languages.
Owner:ADOBE INC
Data center digital twinborn simulation and decision-making system oriented to intelligent management
The invention relates to the technical field of data center management, and discloses a data center digital twinborn simulation and decision-making system oriented to intelligent management. The system comprises a data center physical feature sensing module, a virtual space reconstruction module, an operation situation deduction engine, an abnormal behavior recognition module and a decision instruction generation module. Wherein the physical feature sensing module collects multi-dimensional operation parameters of the infrastructure in real time; the virtual space reconstruction module dynamically constructs a three-dimensional virtual model based on the collected parameters; running a situation deduction engine to simulate a resource scheduling and energy flow process; the abnormal behavior recognition module analyzes the analog data stream to detect an abnormal operation mode; and the decision instruction generation module integrates the abnormal information and generates an optimization regulation and control instruction for the physical equipment. According to the system, intelligent management of the data center is realized through real-time mapping, dynamic deduction and intelligent decision making of physical and virtual spaces, and the management precision and timeliness are improved.

Owner:DALIAN GAODE CREDIT TECH CO LTD
Data center construction and intelligent operation and maintenance management system
The invention relates to the technical field of data center intelligent management, in particular to a data center construction and intelligent operation and maintenance management system, which comprises a dynamic environment sensing module, a heterogeneous equipment protocol adaptation module, a multi-dimensional resource dynamic scheduling module, a hidden fault prediction module and an energy efficiency optimization execution module. Physical environment data such as temperature gradient, current harmonic component and optical fiber strain rate are acquired by deploying a multi-mode sensor, and an environment characteristic matrix is constructed; standard semantic mapping of the heterogeneous protocol is realized by using a semantic slot migration algorithm; establishing a resource topological graph based on the hypergraph neural network and dynamically updating the resource topological graph; a dual-channel space-time convolutional network is adopted to realize fault prediction; and combining the fault probability matrix to generate a dynamic tuning strategy of dimensions such as cooling, electric power, network and the like, and forming closed-loop optimization control. According to the invention, integrated collaboration of multi-source information fusion, equipment intelligent control and energy efficiency adaptive optimization is realized, and the intelligence, reliability and energy efficiency level of data center operation and maintenance are improved.

Owner:SHANDONG ENERGY SHENGLUNENG CHEM ALXA LEAGUE NEW ENERGY CO LTD +1
Data center machine room AI energy-saving control method and system
PendingCN121091656ASingle network parallel feeding arrangementsBiological modelsData centerSimulation
The invention discloses a data center machine room AI energy-saving control method and system, a digital twin model of a machine room operation state is constructed through a holographic perception and heterogeneous data fusion technology, centimeter-level monitoring of an equipment state and environmental parameters is realized, and the system integrates a laser radar array, an acoustic sensor and a gas sensor network. The time-space alignment of multi-modal data is completed by combining edge computing nodes, holographic mapping including thermodynamic characteristics, vibration characteristics and gas leakage risks is formed, historical temperature control strategy characteristics are extracted by adopting a variational auto-encoder based on a dynamic strategy generation mechanism of generative artificial intelligence, and a load trend is predicted by combining a long-short-term memory network. Constructing a self-adaptive strategy pool; the multi-agent reinforcement learning framework enables temperature control, equipment scheduling and power grid response to form game optimization, the strategy robustness in a complex scene is improved, and the system innovatively fuses power grid real-time electricity price and carbon transaction data so as to establish a multi-target decision system.


Owner:SHENZHEN JITON INTELLIGENT TECH CO LTD
Single-phase and two-phase immersion liquid cooling method and system based on AI intelligent decision
The invention relates to the technical field of data center heat dissipation, and particularly provides a single-phase and two-phase immersion liquid cooling method and system based on AI intelligent decision, and the method comprises the steps: injecting coupled data into a dynamic feature extraction engine, and outputting a thermodynamic state evolution tensor which comprises the characteristics of a temperature change rate, a load-heat flux density coupling coefficient and the like; the thermodynamic state evolution tensor is input into the deep neural network model, the temperature and pressure matched with the current thermodynamic state evolution tensor are calculated, and a closed-loop control instruction set capable of being executed by equipment is generated; a closed-loop control instruction set is injected into an execution mechanism set, execution mechanisms execute power reconstruction and flow channel switching according to instructions, gaseous fluorinated liquid is liquefied and flows back through an efficient condenser in a two-phase mode, and heat dissipation mode self-adaptive switching and heat cycle reconstruction are achieved. The system comprises a server, an AI algorithm controller, a cooling liquid storage device, a condenser, a circulating pump, an electric valve, a pressure release valve and a temperature sensor. The heat dissipation efficiency and the system reliability are remarkably improved.

Owner:TIANJIN TIER TECHNOLOGY CO LTD
Precise flow control method and system for two-phase cold plate cooling data center
ActiveCN120835514AEnergy efficient computingCooling/ventilation/heating modificationsData centerCold plate
The invention discloses an accurate flow control method and system for a two-phase cold plate cooling data center, and relates to the technical field of two-phase cold plate cooling, and the method comprises the following steps: S1, collecting multi-mode operation monitoring data in real time, and carrying out the data preprocessing; s2, constructing a multivariable short-time-sequence prediction model, predicting the cooling demand, and performing optimization regulation and control on a cooling demand prediction result; s3, the target regulation and control flow of the cooling liquid is predicted, and flow and cooling execution measures are taken according to the target regulation and control flow prediction result; the opening degree of the valve is accurately adjusted and evaluated in real time, and accurate flow control is achieved; s4, integrating multi-mode operation monitoring data, a cooling demand prediction result, a target regulation and control flow prediction result and a valve opening accurate regulation evaluation result, and constructing a parameter optimization and safety fault-tolerant mechanism; the problems of chip safety and energy consumption risks caused by cold plate temperature overshoot and cooling capacity regulation lag under high-load fluctuation of the server are solved.

Owner:TIANJIN TIER TECHNOLOGY CO LTD
Data center operation and maintenance fault prediction system and method based on deep learning
The invention discloses a data center operation and maintenance fault prediction system and method based on deep learning. The system comprises a multi-source heterogeneous data acquisition module, a data preprocessing module, a deep learning prediction model module and the like. The method comprises the following steps: acquiring multi-dimensional operation data of a data center through full-quantity acquisition of multi-source data, and inputting a CNN-LSTM-Attention hybrid model to realize fault prediction after preprocessing and feature enhancement; fault grades are divided in combination with fault grading, early warning is pushed in multiple channels, a coping strategy is intelligently generated, the effect is verified in a closed loop mode, and finally the model is iteratively optimized. According to the scheme, the fault prediction precision and real-time performance are improved, the operation and maintenance response time is shortened, the service interruption risk caused by faults is reduced, and the method is suitable for efficient operation and maintenance of large-scale data centers.

Owner:SHANGHAI DIPU XINCHENG INTELLIGENT TECH CO LTD
Data center energy efficiency optimization method and system
PendingCN120596961ANeural architecturesCooling/ventilation/heating modificationsThermodynamicsData center
The invention provides a data center energy efficiency optimization method and system. A data acquisition node is arranged at the inlet end of a cooling unit to obtain refrigerant transportation data, the data are input into a path optimization model constructed based on a physical topological structure of the cooling unit, and a dynamic adjustment coefficient set containing heat exchange efficiency, phase change delay and pressure compensation parameters is generated. Meanwhile, the temperature difference generating capacity is converted into a driving parameter set based on the heat source distribution map by obtaining the surface waste heat of the cooling unit. And in combination with the dynamic adjustment coefficient set and the driving parameter set, the temperature gradient compensation amount, the phase change trigger threshold value and the pressure balance interval are determined, joint optimization is carried out, and a refrigerant flow rate control scheme adapting to machine room environment temperature fluctuation is generated. And energy efficiency optimization of the data center machine room environment is realized based on the refrigerant circulation parameters. According to the technical scheme provided by the invention, the energy efficiency optimization effect of the data center is remarkably improved by optimizing the flow speed control of the refrigerant.

Owner:TIANJIN UNIV
Data center operation and maintenance service environment monitoring system
The invention relates to the technical field of line arc abnormity monitoring, in particular to a data center operation and maintenance service environment monitoring system which comprises a multi-mode sensing unit, a dynamic baseline modeling unit, a transition state abnormity extraction unit and a grading early warning unit. The dynamic baseline modeling unit builds a three-layer safety baseline model, the base layer builds harmonic references in a segmented mode according to the load rate, the environment layer generates voiceprint feature template libraries of different temperature and humidity intervals, the time layer fits a 24-hour change trend envelope line, and the transition state anomaly extraction unit separates and decouples an arc voiceprint feature frequency band through a blind source and calculates the energy ratio. The harmonic abrupt change phase deviation amplitude is analyzed in combination with window sliding correlation, the abnormal evolution index is generated through fusion, the graded early warning unit triggers response according to the index, transition state abnormity is accurately recognized, the perspectiveness and reliability of operation and maintenance early warning are improved, and the method is suitable for safe operation and maintenance of data center equipment.

Owner:LINYI NEW SMART CITY OPERATION CO LTD
Intelligent agent collaborative optimization data center management system based on knowledge graph driving
The invention discloses an agent collaborative optimization data center management system based on knowledge graph driving, and relates to the technical field of data center management. The system specifically comprises the following modules: a modeling and entity management module, a cross-regional global scheduling optimization module, an agent game negotiation optimization module, an agent trust management module, a game negotiation conflict identification module, a reasoning evidence management module and a cross-regional consistency verification module. By establishing a complete knowledge graph model, systematic modeling of resource attributes, constraints, historical decisions and strategy preferences is realized, a unified data basis is provided for negotiation among multiple agents, the problem of a suboptimal solution caused by information asymmetry is effectively solved, a hierarchical reasoning mechanism is adopted, and the probability of resource disruption is reduced. In combination with global-region-node three-level reasoning and multi-round game negotiation, recursive optimization from global to local is realized, the reasoning complexity is effectively reduced, and the negotiation efficiency is improved.


Owner:北京紫翰科技有限公司
Embedded system construction method and device
The invention discloses an embedded system construction method and device, and the method comprises the steps: loading a configuration file which is a. Config file generated based on configuration parameters selected by a user through a visual configuration interface; when the CONFIGCONANAUTOUPDATE flag bit is detected to be in an activated state, the Conan warehouse data center is accessed, the latest compatible version of each Conan software package dependency item is inquired, and a semantic version constraint analysis algorithm is adopted to update a version identifier in the configuration file into the latest compatible version; generating a description file containing a dependency item list based on the updated configuration file, and generating a dependency lock file through a Hash locking mechanism; and importing the pre-compiled binary package into the construction environment, calling the corresponding pre-compiled binary package according to the version information and the Hash check value in the dependency lock file in the firmware compiling process, and executing hierarchical compiling operation.

Owner:BEIJING ZHONGCHEN MICROELECTRONICS CO LTD
Anti-electromagnetic interference method for flywheel energy storage system of data center
PendingCN120979007AElectrical storage systemDigital adaptive filtersInterference resistanceData center
The invention relates to the technical field of anti-electromagnetic interference, in particular to an anti-electromagnetic interference method for a flywheel energy storage system of a data center, which comprises the following steps: acquiring change rate data of the rotating speed and the angular speed of a flywheel, judging the attribution of a disturbance interval, recording change characteristics, extracting an interference identifier, comparing the interference identifier with impedance change, and generating a switching node. Frequency response and reflection coefficient characteristics of the filtering unit are detected, a coupling channel generation label is identified, and output fluctuation is evaluated to generate an anti-interference capability state label. According to the method, the surface resistivity of the shielding layer is dynamically switched according to the comparison result of the specific interference triggering identification bit and the signal link impedance change state in each disturbance stage through classification judgment and correlation marking of inertial disturbance, so that the effect of suppressing electromagnetic interference in real time is optimized; the influence degree of electromagnetic interference can be dynamically evaluated in the system operation process, and the adaptability of the energy storage system to the electromagnetic interference is judged and adjusted in real time.

Owner:SHENYANG MICRO CONTROL ACTIVE MAGNETIC LEVITATION TECH IND RES INST CO LTD
Energy consumption prediction and scheduling control method based on machine learning
The invention discloses an energy consumption prediction and scheduling control method based on machine learning. According to the method, operation parameters, energy consumption curves and environment disturbance data of multiple devices are collected through a distributed sensing terminal, the data are input into a pre-trained machine learning model, and a probability prediction result of future energy consumption distribution is generated. On the basis of prediction, an intervention signal is applied in an equipment safety boundary, equipment response characteristics are obtained according to the difference before and after intervention, and an energy consumption risk map is constructed by combining the equipment response characteristics with a probability prediction result. And based on the energy consumption risk map, generating an extreme disturbance scene by using digital twinning, performing consistency check on a probability prediction result and a scheduling scheme in a data domain and a physical domain, and performing multi-stage scheduling in combination with task delays to generate a scheduling result. And finally, issuing the scheduling result to the equipment. The method can improve the accuracy of energy consumption prediction and the reliability of scheduling decision making, and is suitable for intelligent management of data centers, industrial production and high-energy-consumption scenes.

Owner:CLIMAVENETA CHATUNION REFRIGERATION EQUIP SHANGHAI
Dynamic flow control method for two-phase cold plate liquid cooling system based on multi-mode perception
The invention discloses a dynamic flow control method for a two-phase cold plate liquid cooling system based on multi-modal sensing, and relates to the technical field of equipment cooling. Comprising the following steps: S1, collecting liquid cooling monitoring data in real time, and performing data preprocessing; s2, judging the state risk of the cold plate, carrying out signal cross validation, and taking an abnormal regulation and control measure; s3, cooling liquid flow regulation and control are carried out, and the matching degree of flow regulation and control and chip thermal load is evaluated, so that flow regulation and control correction is carried out; and S4, constructing a big data modeling and simulation feedback platform, evaluating a flow regulation and control self-healing effect, optimizing each parameter and strategy, and carrying out self-learning evolution. The problems that an existing two-phase cold plate liquid cooling system generally only depends on a single temperature signal, lacks a multi-source redundancy check mechanism, has the problems of response lag, weak local reflection capacity, high risk during failure and the like, consequently, the cooling capacity distribution and adjustment precision is insufficient, and the actual requirement of a high-heat-density data center for heat dissipation is difficult to meet are solved.

Owner:TIANJIN TIER TECHNOLOGY CO LTD
Intelligent energy consumption management system and method for AI computing power equipment based on big data
The invention discloses an AI computing power equipment intelligent energy consumption management system and method based on big data, and relates to the technical field of data center energy consumption management, the method comprises the following steps: obtaining real-time operation data of AI computing power equipment, the real-time operation data comprising load characteristic parameters, energy consumption characteristic parameters, environment characteristic parameters and equipment state parameters; obtaining a load discrimination value according to the load characteristic parameter; obtaining an energy consumption discriminant value according to the energy consumption characteristic parameters; acquiring an environment discrimination value according to the environment characteristic parameters; acquiring a state discrimination value according to the equipment state parameter; fusing the load discriminant value, the energy consumption discriminant value, the environment discriminant value and the state discriminant value to generate a comprehensive energy efficiency index; judging whether the comprehensive energy efficiency index exceeds a preset dual-threshold decision interval or not; if the upper limit threshold value is exceeded, triggering graded consumption reduction response, including dynamic frequency modulation, task migration or equipment dormancy; and if so, determining that the current operation mode is in a high-energy-efficiency state and maintaining the current operation mode.

Owner:WUHAN SPARK ZHONGDA INFORMATION TECH CO LTD
AI-Based Incentive Platform for Real-Time Dispatch of Flexibility Resources in Unlocking Grid Capacity
A system and method for enabling real-time dispatch of flexibility resources to unlock grid capacity through AI-based orchestration. The invention addresses the challenge of connecting high energy demand users, such as data centers, to constrained electricity grids without requiring infrastructure upgrades. The system establishes a marketplace where flexible asset holders set temporal compensation prices and boundary conditions, enabling true market-based participation. An AI orchestration engine analyzes real-time grid conditions and modifies flexible asset behavior to create inverse consumption profiles that counterbalance new demand loads. The platform integrates hardware and software solutions for remote control and APIs for autonomous systems like electric vehicles. Aggregators and off-takers can establish long-term contracts for flexible capacity at agreed prices. The AI system ensures flexible assets meet user-defined boundary conditions while simultaneously masking high energy demand, making new loads invisible to the grid and enabling immediate connection of data centers essential for industrial deployment.


Owner:ESCROW-TECH LTD
Waste heat recovery scheduling method and system for two-phase cold plate of data center
The invention discloses a waste heat recovery scheduling method and system for a two-phase cold plate of a data center, and relates to the technical field of refrigeration and heat management. The waste heat recovery scheduling method and system for the two-phase cold plate of the data center comprises the following steps that S1, key thermal parameters and tail end state variables are collected through multiple types of thermal monitoring devices, and thermal state monitoring data are obtained and preprocessed; s2, on the basis of the thermal state monitoring data and in combination with an SLA configuration file, performing priority division on the heat utilization terminals, and constructing a scheduling deviation judgment mechanism to identify thermal state changes; s3, under driving of the regulation and control instruction, accessing multi-source waste heat and distributing the multi-source waste heat to each terminal scene, and evaluating a matching condition of the waste heat and a terminal demand; and S4, based on the change of the heat distribution state and the thermal state monitoring data, identifying an overload risk in combination with a multi-parameter linkage mechanism. The problems that waste heat recovery is insufficient and the energy utilization rate is limited under the light-load and multi-heat-source cooperative working condition are solved.

Owner:TIANJIN TIER TECHNOLOGY CO LTD
Information interaction method and system for cooperative scheduling of computing power and electric power of data center
The invention relates to the technical field of data center interaction, and particularly discloses an information interaction method and system for computing power and electric power collaborative scheduling of a data center, which integrates multi-source heterogeneous data and constructs a space-time correlation model to realize accurate prediction and dynamic modeling of resource demands of the data center. The real-time learning ability of the DRL and the discrete decision advantage of the MIP are utilized to realize multi-objective synchronous optimization, the energy efficiency and economy of the data center are significantly improved, the multi-objective optimization can realize "computing power-electric power-heating power" coupling, the block chain technology ensures that data cannot be tampered and is transparent and credible, the security and auditing performance of the system are improved, and the system performance is improved. Carbon footprint tracking, green power authentication and PUE index dynamic energy efficiency optimization are supported, green power use is directly stimulated, the carbon footprint and operation cost is reduced, thermal data is used for cooling control, power data is used for task scheduling, resource conflicts are avoided, the limitation of traditional single resource scheduling is broken through, and the response speed is increased.

Owner:UNIV OF CHINESE ACAD OF SCI
Dynamic scheduling method and system for satellite-ground cooperative computing task
The invention discloses a dynamic scheduling method and system for a satellite-ground cooperative computing task, and the method comprises the following steps: constructing a satellite-ground cooperative computing system comprising a remote sensing satellite cluster, a satellite server node, a ground server / data center and the like, and enabling the satellite cluster to generate an in-orbit task and to describe dependence through DAG; available computing power, task queues and other resource states of a satellite and a ground server are collected in real time, and global observation is formed; on the basis of an MADRL framework, each node is regarded as an independent agent, a task allocation action is generated through a strategy network, and a collaborative decision is modeled through POMDP; optimizing the task execution sequence of the same node by using an EFT algorithm; issuing a task and monitoring execution; task completion time and energy consumption are collected, and a network optimization strategy is updated through a reward function and experience playback; the scheduling strategy is adjusted through loop iteration, satellite offline and link fluctuation are adapted, and the resource utilization rate and the task processing efficiency are improved.

Owner:HARBIN INSTITUTE OF TECHNOLOGY (SHENZHEN) (INSTITUTE OF SCIENCE AND TECHNOLOGY INNOVATION HARBIN INSTITUTE OF TECHNOLOGY SHENZHEN)
Heterogeneous system integration and fault diagnosis operation and maintenance system based on big data analysis
The invention discloses a heterogeneous system integration and fault diagnosis operation and maintenance system based on big data analysis, and the system is characterized in that the system comprises an acquisition cleaning module which is used for collecting structured data, semi-structured data and non-structured data, and carrying out the data cleaning; the mapping calculation module is used for dynamically mapping the cleaned data, and storing the data into a database after federal calculation; the feature extraction module is used for performing multi-modal extraction on the data in the database, constructing a knowledge graph and generating features for fault diagnosis; the model training module is used for constructing a fault diagnosis model and performing fault prediction and root cause analysis by using fault diagnosis features; the collaborative decision-making module is used for carrying out collaborative decision-making on the edge and the cloud according to the analysis result; and the feedback optimization module is used for feeding back the response processing result to the data center and carrying out updating iteration on the diagnosis model.

Owner:YANCHENG ZHIWANG TECH CO LTD
Machine room monitoring method and system based on multi-source data fusion intelligent inspection robot
The invention discloses a machine room monitoring method and system based on a multi-source data fusion intelligent inspection robot, and belongs to the technical field of machine room automatic monitoring, and the method comprises the steps: applying adversarial transfer learning on a four-dimensional fault semantic feature field, and generating a cross-modal causal atlas representing a fault evolution path through a graph neural network; according to the method, a loss function is combined to align feature distribution of a standard machine room and a current machine room, a gradient inversion layer is utilized to force feature distribution alignment of a source domain and a target domain, meanwhile, an attention mechanism and a causal strength weight are combined to generate a cross-modal causal atlas, and a graph neural network further models physical connection, functional dependence and time sequence association between nodes, so that the cross-modal causal atlas is obtained. A causal relationship is coded into an edge weight, noise correlation is filtered through a causal mask, the stability of the causal atlas is improved, and the cross-modal causal atlas can accurately capture a fault propagation path.

Owner:BEIJING AIR WORLD SCI & TECH CO LTD
Water-cooling energy consumption self-adaptive regulation and control method suitable for data center
InactiveCN121174454AEnergy efficient computingCooling/ventilation/heating modificationsData centerControl theory
The invention discloses a water-cooling energy consumption adaptive regulation and control method suitable for a data center, and the method comprises the following steps: obtaining a multi-dimensional operation parameter set of the data center in real time, and generating a real-time thermal load density distribution diagram reflecting the heat distribution condition in a machine room; calculating the overall thermal deviation degree and the local hot spot intensity, and solving through a dynamic energy efficiency optimization function to obtain a target system supply and return water temperature difference and a target cooling liquid flow; inputting into a hydraulic and thermodynamic simulation model, and generating an optimal multi-device coordinated regulation instruction set; and executing the multi-device coordinated regulation instruction set, and then performing parameter calibration on the hydraulic and thermodynamic simulation model. The method has the following advantages and effects that the thermal environment of the machine room can be sensed in real time, the energy consumption and heat dissipation requirements can be intelligently balanced, and multiple devices in the cooling system can be cooperatively regulated and controlled, so that the overall energy consumption of the cooling system is optimized while the local overheating risk of the machine room is thoroughly eliminated.

Owner:SHENZHEN SENOS SUPPLY CHAIN CO LTD
Multi-data center multi-computing power collaborative optimization method and system based on computing power and refrigeration system comprehensive energy consumption cost, and storage medium
The invention discloses a multi-data center multi-computing power collaborative optimization method and system based on computing power and refrigeration system comprehensive energy consumption cost, and a storage medium. The method comprises the following steps: S1, uniformly dividing a total conventional computing power resource and a total intelligent computing power resource which need to be scheduled into a plurality of sub-computing power resources; s2, sequentially allocating and starting a data center for each conventional sub-computing power resource; S2.1, calculating the cost of each data center after the conventional sub-computing power resource is started, and selecting to start the data center with the minimum cost; s2.2, repeating the step S2.1 until the total conventional computing power resource needing to be scheduled is reached; s3, sequentially allocating and starting a data center for each intelligent sub-computing power resource: S3.1, solving an optimal operation period deployment scheme of the intelligent sub-computing power resource in each data center through a genetic algorithm, calculating the cost after starting the intelligent sub-computing power resource according to the optimal operation period deployment scheme, and selecting to start the intelligent sub-computing power resource with the minimum cost; s3.2, repeating the step S3.1 until the total intelligent computing power resource needing to be scheduled is reached; according to the method, the computing power resource operation cost can be minimized.

Owner:STATE GRID ELECTRIC POWER RES INST +2
SMT patch deviation correction system linked with AOI and method thereof
The invention provides an SMT patch correction system linked with AOI and a method thereof. The SMT patch correction system comprises a stokehole AOI detection module, a stokehole AOI detection module, a multi-dimensional sensing module, an intelligent data center module, an AI decision optimization module and a process simulation verification module. According to the method, the AOI detection data in front of and behind the furnace are fused through the intelligent data center module, the mapping relation of knowledge graph associated elements, the technology and offset data is constructed, a linkage closed loop is formed, and offset source tracing and full-process dynamic deviation correction are achieved; environmental parameters such as temperature, vibration and suction nozzle pressure are collected in real time through the multi-dimensional sensing module, and the environmental parameters are standardized through an intelligent data platform and then are included into correction logic of the AI decision optimization module, so that dynamic compensation of the influence of environmental factors on the mounting precision is realized; a deep learning and reinforcement learning cooperation strategy is adopted through the AI decision optimization module, parameters are dynamically optimized and corrected in combination with thermal deformation simulation and other multi-source information of the process simulation verification module, and the adaptability to different element types and production scenes is improved.

Owner:KUNSHAN ZHENSHUN ELECTRONIC TECH CO LTD
Data center IT load and cooling system cooperative control method based on TD3 algorithm
The invention provides a data center IT load and cooling system cooperative control method based on a TD3 algorithm, and relates to the field of deep reinforcement learning, and the method comprises the steps: obtaining an initial data set representing the server state, environment and task characteristics of a data center, and processing the initial data set to obtain a target data set; building a deep reinforcement learning model which is based on a TD3 algorithm and comprises a strategy network Actor and a value network Critic, and determining a state space, an action space and a reward function of the model; training the model to obtain a target model; and outputting a work task allocation strategy and a cooling system regulation and control strategy through interaction of the target model and the environment. According to the target model, by outputting the work task allocation strategy and the cooling system regulation strategy, work task allocation can be guided, operation of the cooling system can be controlled, the IT load of the server and refrigeration balance of the cooling system are achieved, safe and stable operation of the server is ensured, and energy consumption of the cooling system is reduced.

Owner:HEFEI UNIV OF TECH
Multi-data center computing power-electric power cooperative scheduling and demand response declaration capacity optimization method
The invention provides a multi-data center computing power-electric power cooperative scheduling and demand response declaration capacity optimization method, which comprises the following steps of: firstly, acquiring multi-dimensional historical time sequence data of a data center; a machine learning algorithm is used to predict the workload of each data center in each time period of a future single day in a future scheduling period and the power market price of the place where each data center is located, and then a space-time coupling-oriented multi-data center computing power-power cooperation model considering uncertainty is constructed; the collaborative model comprises a joint optimization framework of computing power scheduling and power scheduling, and takes actual profit maximization as a target, then the established collaborative model is converted into a mixed integer linear programming problem and solved, and the optimal declaration capacity of each data center participating in demand response is obtained; and each data center carries out scheduling according to the task load of space migration and time migration, the charging and discharging power of an energy storage system and the power generation amount of renewable energy sources, so that overall optimization of demand response declaration capacity of the multiple data centers is realized.

Owner:XIAMEN UNIV
Port operation state sensing and monitoring system based on data medium station
The invention relates to the technical field of port operation state sensing and monitoring, and particularly discloses a port operation state sensing and monitoring system based on a data center, which monitors a wind speed value and a visibility value at each current time point in real time through a micro weather station array, and synchronously obtains tidal phase data of an observatory. Comprehensively generating multi-dimensional meteorological data in a set time period; dynamically calculating the berthing safety coefficient of the target ship through a multi-dimensional constraint condition in combination with the load tonnage of the target ship; according to the target ship berthing safety coefficient, a dynamic ship berthing strategy of the target ship is generated; through comprehensive application of multi-dimensional meteorological data acquisition, berthing safety coefficient calculation, dynamic ship berthing strategy generation and a feedback terminal, a port manager can monitor and optimize the ship berthing process in real time. Therefore, the operation safety and efficiency of the port are improved, a more scientific and flexible berthing scheme is provided for the ship, and the sustainability and economic benefits of port operation are ensured.

Owner:YANTAI PORT GRP CO LTD +1
Automatic power regulation and control method for micro-grid
ActiveCN120784858AGeneration forecast in ac networkLoad forecast in ac networkData centerResource coordination
The invention discloses a micro-grid automatic power regulation and control method, and relates to the technical field of micro-grid power regulation and control and resource management. In order to solve the defects of poor new energy consumption capability, high distributed resource management difficulty, poor power grid regulation and control flexibility, poor resource cooperation effect and poor power and load prediction accuracy of an existing micro-grid power regulation and control method, grid-connected and off-grid flexible switching of a power grid A and a power grid B is realized by constructing an integrated construction framework. And multi-source data are integrated, and new energy power generation and load demands are intelligently predicted through data center management. And during grid connection, the distribution and dispatching integrated system determines power dispatching, and the micro-grid management system B makes a dispatching plan. And during off-grid, power is supplied according to the user priority. And in the grid-connected and off-grid mode, power distribution, load regulation and control and resource optimization configuration are carried out, and distributed resources are regulated and controlled in real time through the coordination controller, so that stable operation of the power grid is ensured. The method is mainly used for flexibly regulating and controlling the micro-grid.

Owner:DONGFANG ELECTRONICS CO LTD
Task processing method and device based on domain knowledge base, equipment and medium
The invention relates to the technical field of artificial intelligence, can be applied to business scenes of data center operation and maintenance, financial science and technology, medical treatment and health and the like, and discloses a task processing method and device based on a domain knowledge base, equipment and a medium. Cleaning and formatting to generate standardized task list data, inputting the standardized task list data and a domain knowledge base into a language model to generate structured task list data, and matching task list types based on the structured task list data to generate a task list execution plan, and determining an execution mode according to the task list execution plan and executing to generate a task list execution state. Through cooperative processing of the domain knowledge base and the language model, standardized and structured processing of task list data is realized, and in combination with task type matching and execution mode control, processing automation and accuracy are improved, manual participation is reduced, and response speed and efficiency are improved.

Owner:PING AN TECH (SHENZHEN) CO LTD