

Patents
Literature
40 results about "Cellular mechanism" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
What is Cellular Mechanism. 1. It involves all those transport ways through which xylem transport heavy metal from soil to different parts of plant including uptake, sequestration and translocation methods.
Novel application of biosensors for diagnosis and treatment of disease
A method for detecting compounds of interest in bodily fluids, including exhaled breath and blood. The present invention uses biosensors that mimic naturally occurring cellular mechanisms, including RNA oligonucleotide chains or “aptamers,” in combination with signaling agents or nanotechnology to provide an effective and efficient method for diagnosing a condition and / or disease within a patient. The subject invention also provides a method for screening those analytes / biomarkers likely to be present in exhaled breath.
Owner:UNIV OF FLORIDA RES FOUNDATION INC
Application of biosensors for diagnosis and treatment of disease
InactiveUS6974706B1Easy to detectEvaluating efficacyMaterial nanotechnologyMicrobiological testing/measurementDiseaseCellular mechanism
A method for detecting compounds of interest in bodily fluids, including exhaled breath and blood. The present invention uses biosensors that mimic naturally occurring cellular mechanisms, including RNA oligonucleotide chains or “aptamers,” in combination with molecular beacons or nanotechnology to provide an effective and efficient method for diagnosing a condition and / or disease within a patient. The subject invention also provides a method for screening those analytes / biomarkers likely to be present in exhaled breath.
Owner:FLORIDA UNIV OF A FLORIDA
Targeted chromosomal mutagenasis using zinc finger nucleases
The present invention provides for a method or methods of targeted genetic recombination or mutagenesis in a host cell or organism, and compositions useful for carrying out the method. The targeting method of the present invention exploits endogenous cellular mechanisms for homologous recombination and repair of double stranded breaks in genetic material. The present invention provides numerous improvements over previous mutagenesis methods, such advantages include that the method is generally applicable to a wide variety of organisms, the method is targeted so that the disadvantages associated with random insertion of DNA in-to host genetic material are eliminated, and certain embodiments require relatively little manipulation of the host genetic material for success. Additionally, it provides a method that produces organisms with specific gene modifications in a short period of time.
Owner:UNIV OF UTAH RES FOUND
Method to measure the activation state of signaling pathways in cells
InactiveUS20020127604A1Microbiological testing/measurementWithdrawing sample devicesDiseaseSignalling pathways
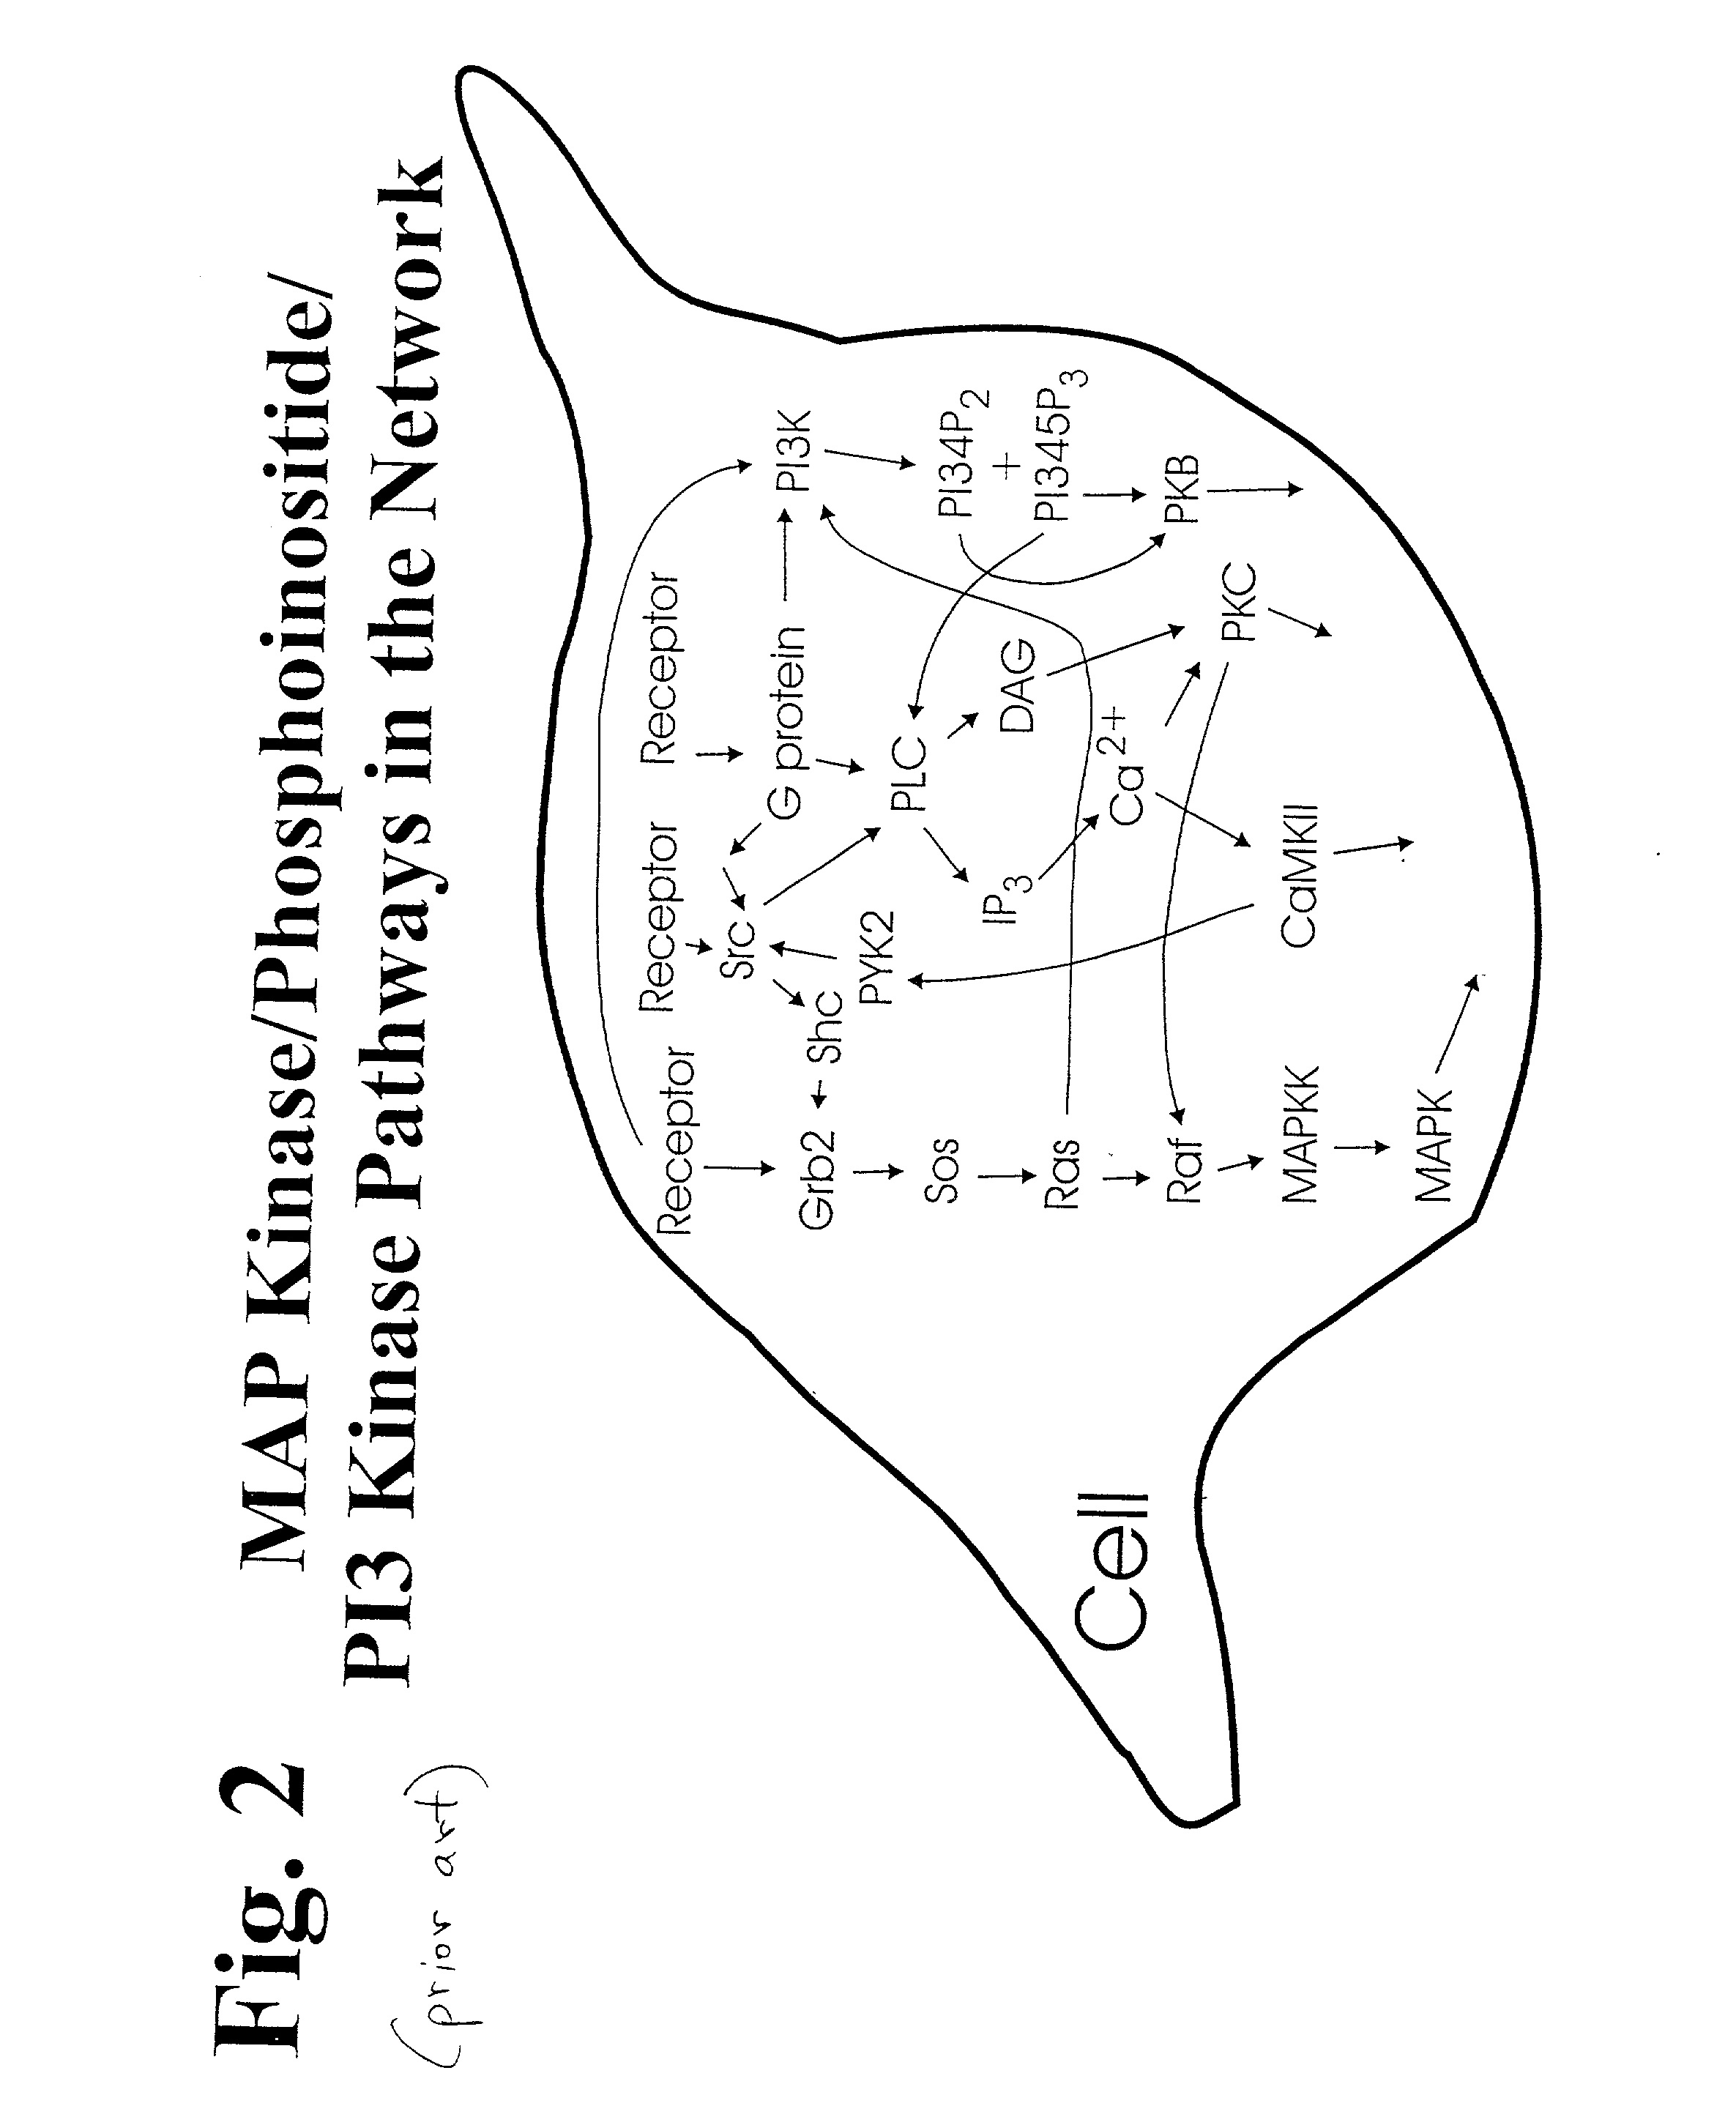
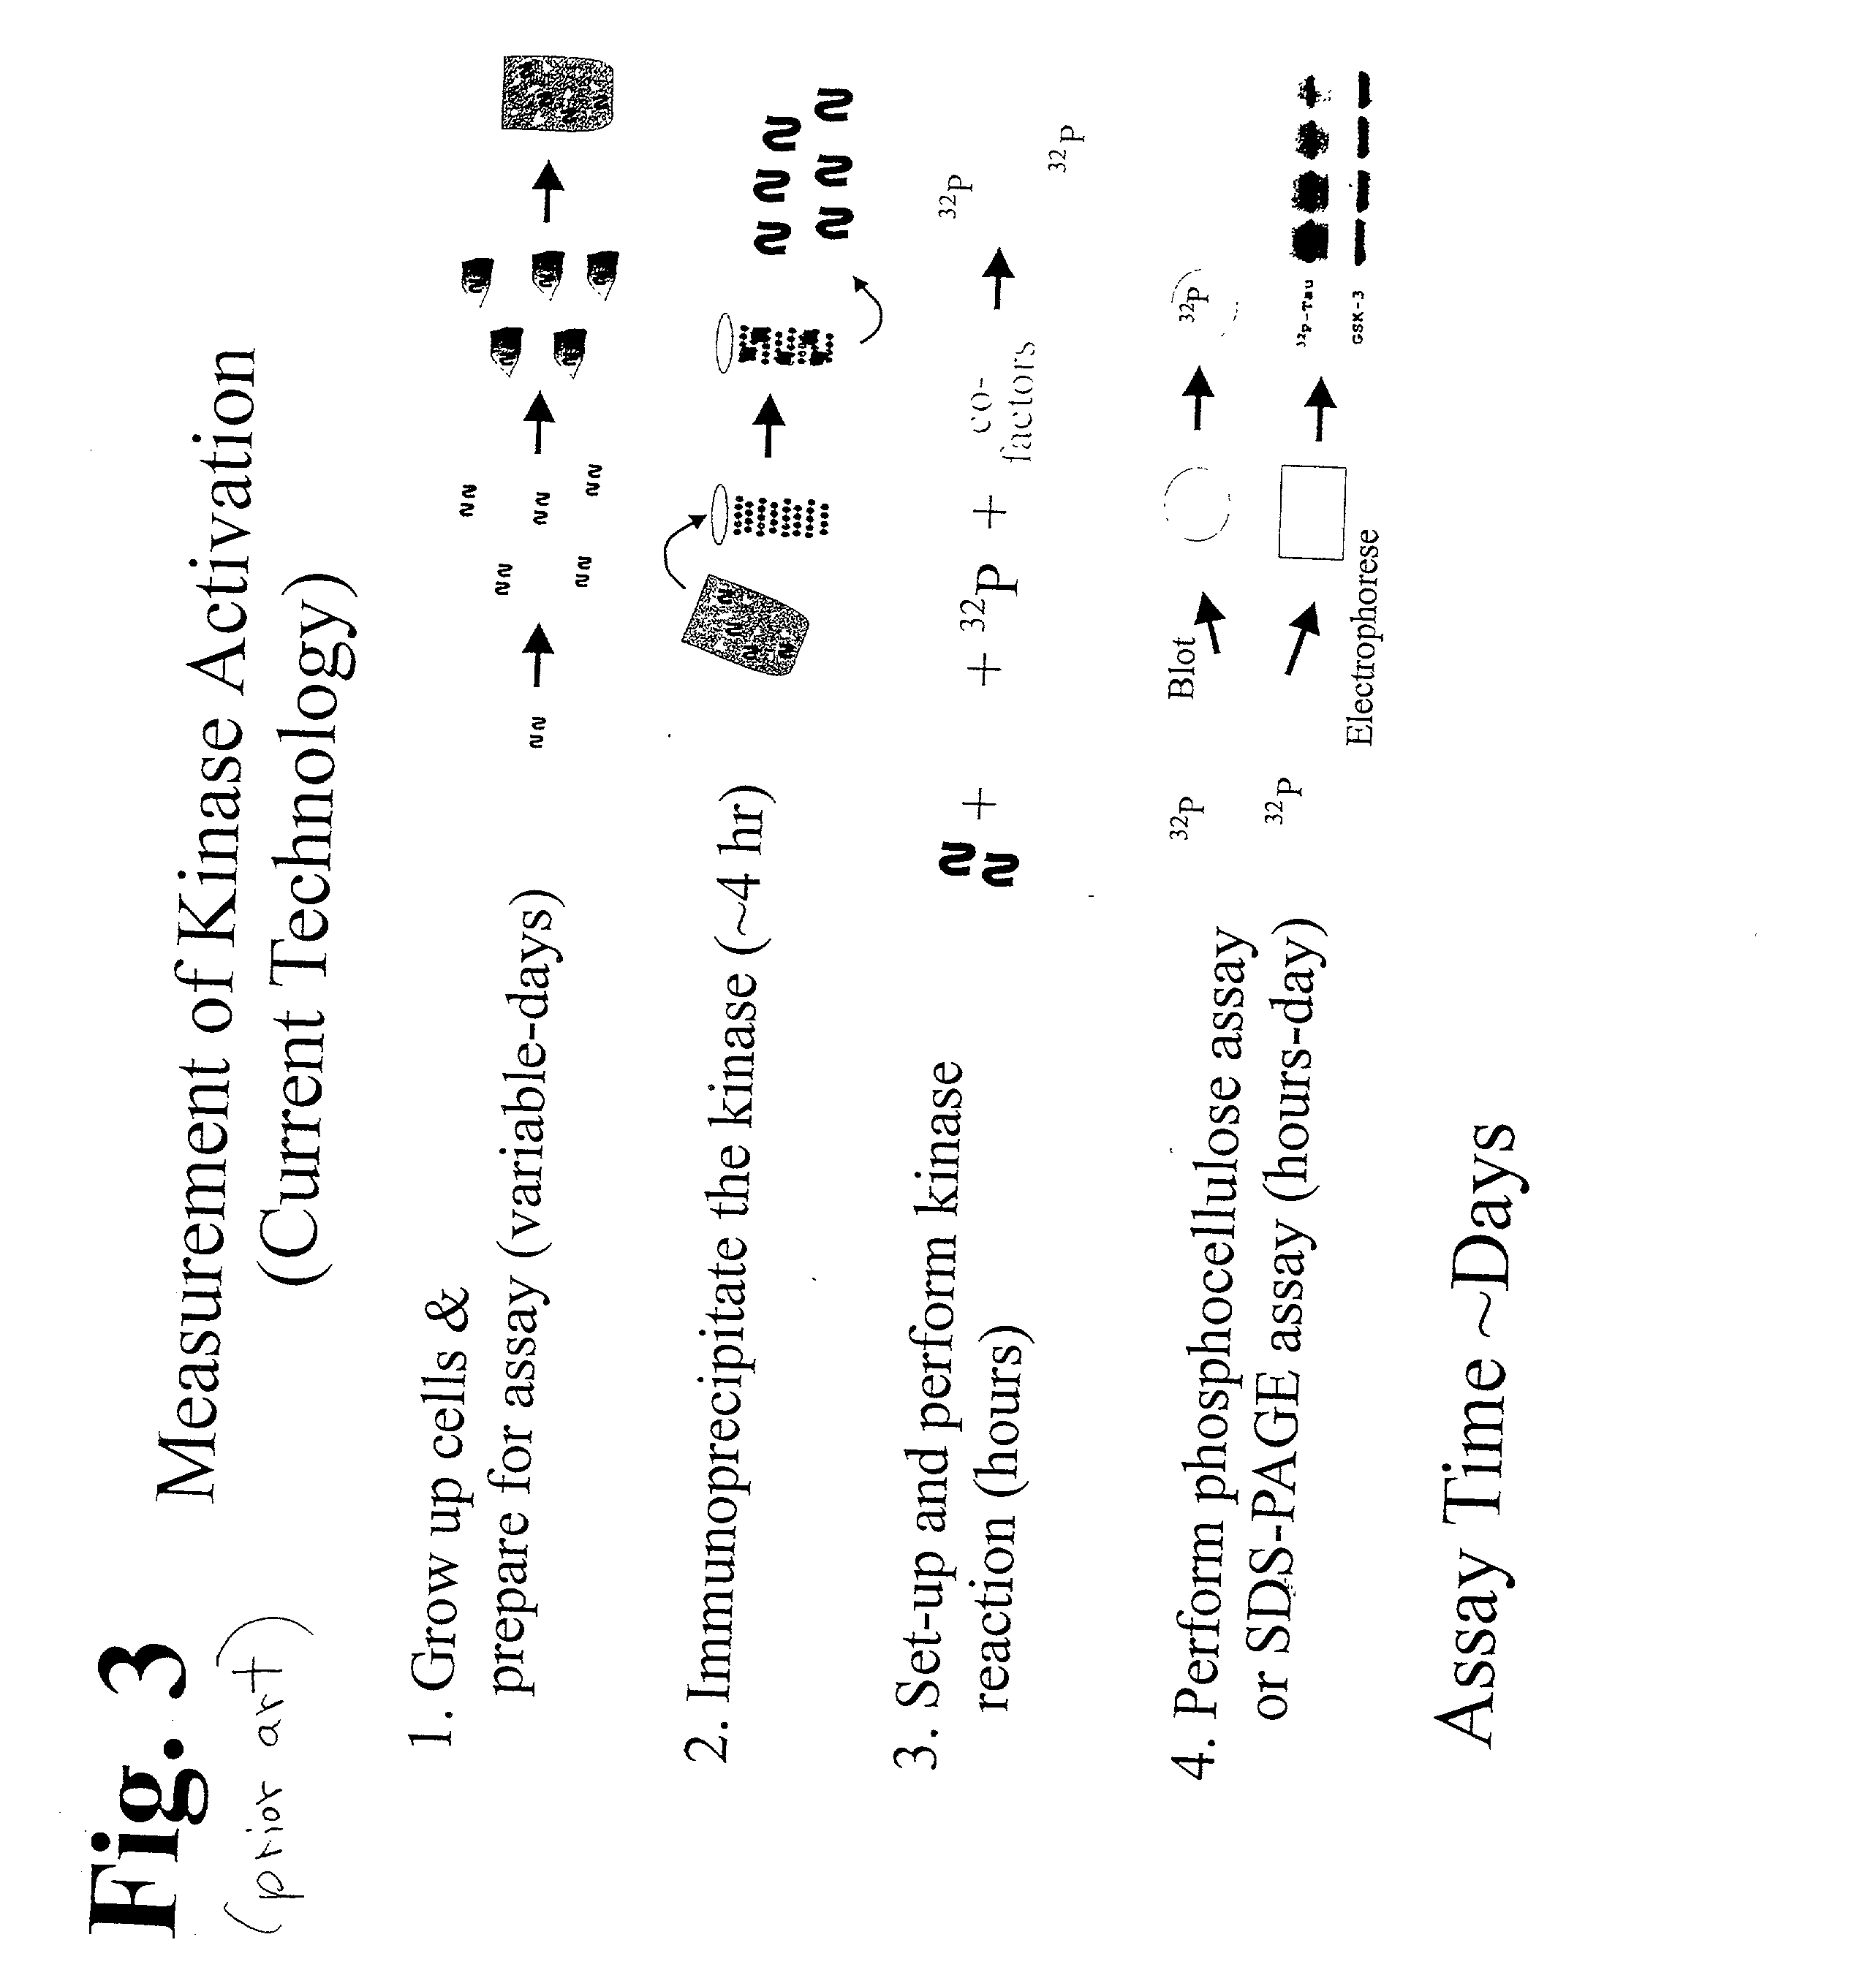
The activity of multiple proteins in a single living cell, portion of a cell or in a group of cells is simultaneously measured by introducing reporter molecules. The reporter(s) is chemically modified by the enzyme of interest. In some cases the enzyme(s) is affected by the addition of a stimulus or a pharmaceutical compound to the cell. The reactions between the enzymes and the reporters are diminished or terminated, and the reporter and modified reporter are removed. The activity of the enzyme(s) is determined by measuring the amount of reporter remaining, the amount of altered reporter produced, or by comparing the amount of reporter to the amount of altered reporter. A database is compiled of the activities of the different proteins. By performing a series of experiments at different time points, conditions, and varieties of cell types, a database is developed for molecular cellular mechanisms in health and disease states. By exposing cells to a variety of compounds data for drug development and screening is provided.
Owner:RGT UNIV OF CALIFORNIA
Method to measure the activation state of signaling pathways in cells
InactiveUS7236888B2Microbiological testing/measurementWithdrawing sample devicesSignalling pathwaysCellular mechanism
The activity of multiple proteins in a single living cell, portion of a cell or in a group of cells is simultaneously measured by introducing reporter molecules into the cell(s) or a portion thereof, chemically modifying the reporter(s) by the enzyme of interest, terminating the modification reactions, removing the reporter(s) and modified reporter(s), and determining the amount of enzyme activity present by measuring or comparing the amount of reporter(s) and modified reporter(s) present. By performing a series of experiments at different time points, conditions, and varieties of cell types, a database is developed for molecular cellular mechanisms in health and disease states. By exposing cells to a variety of compounds data for drug development and screening is provided.


Owner:RGT UNIV OF CALIFORNIA
Pseudocomplementary oligonucleotides for targeted gene therapy
ActiveUS8309356B2Increase flexibilityImprove efficiencySugar derivativesCarbohydrate active ingredientsCellular mechanismDouble stranded
Owner:YALE UNIV
Targeted Chromosomal Mutagenesis Using Zinc Finger Nucleases
Owner:UNIV OF UTAH RES FOUND
Three-dimensional culture containing human articular chondrocytes with induced terminal differentiation changes, and preparation process and uses of the same
ActiveUS20080026362A1Induce changeMicrobiological testing/measurementArtificial cell constructsDiseaseBiological property


Owner:KAOHSIUNG MEDICAL UNIVERSITY
Treatment Solution and Method for Preventing Posterior Capsular Opacification by Selectively Inducing Detachment And/Or Death of Lens Epithelial Cells
InactiveUS20070129286A1Great incidencePrevent PCOBiocideSenses disorderIon distributionCellular mechanism
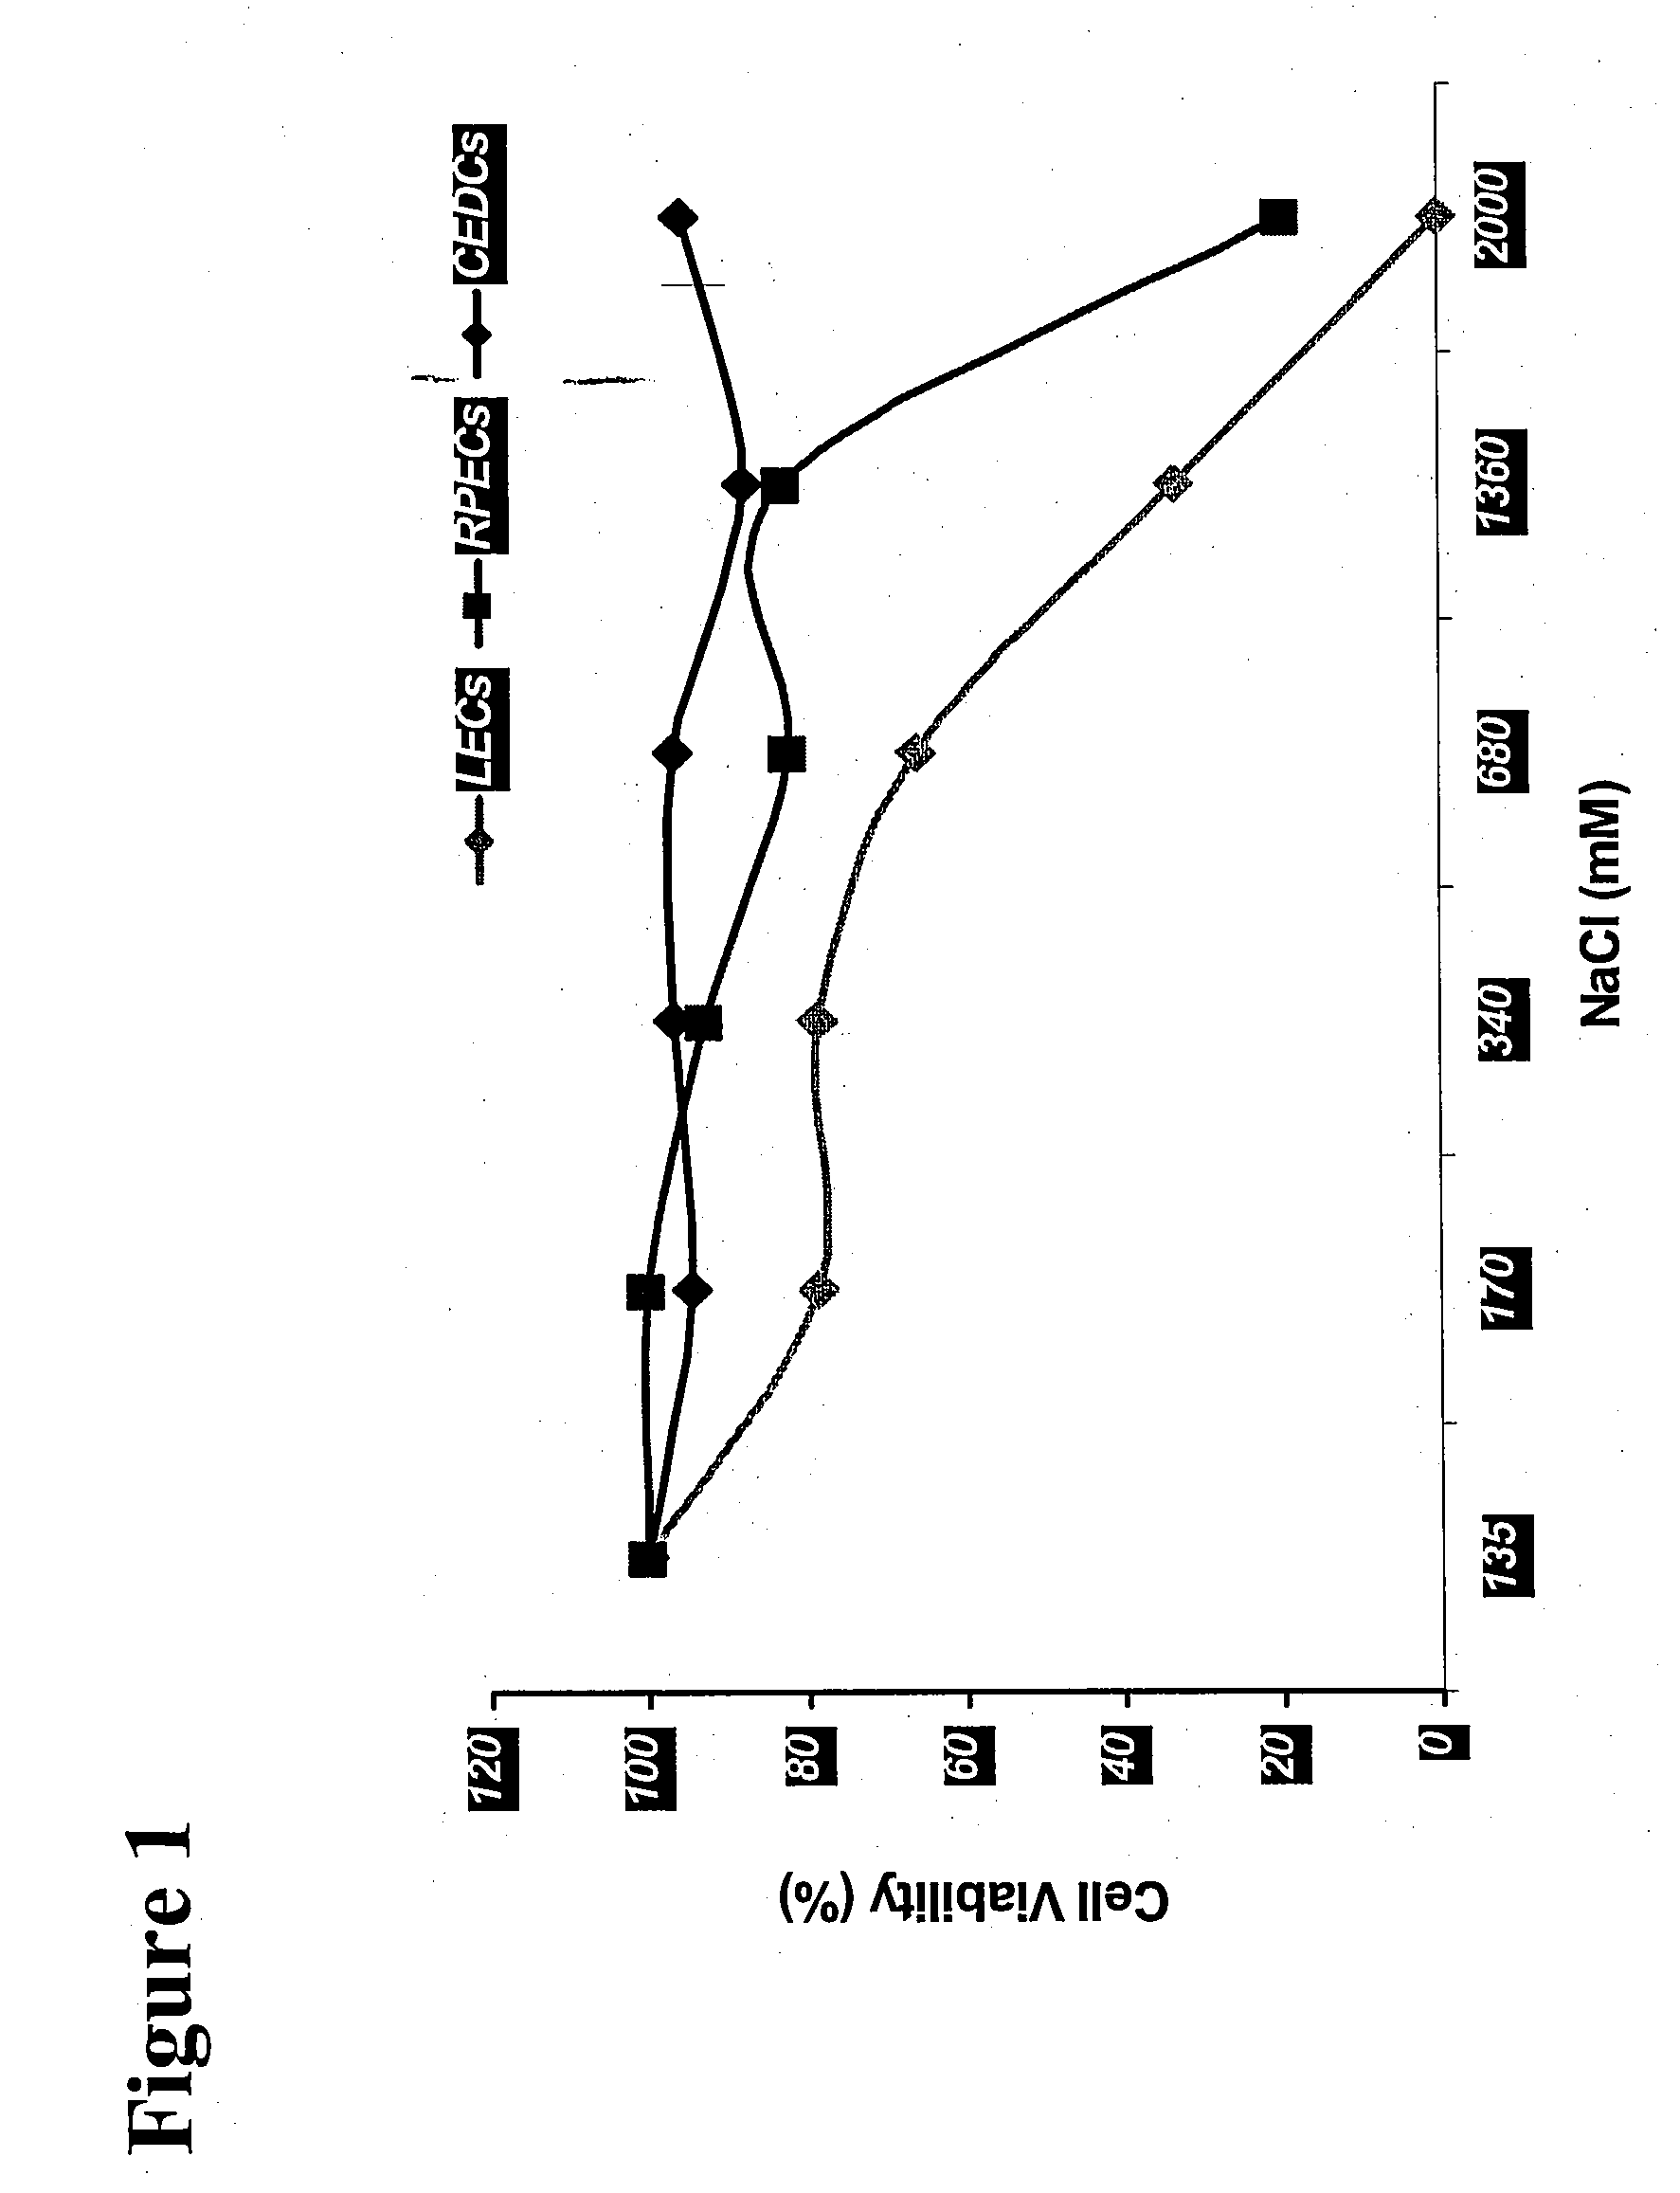
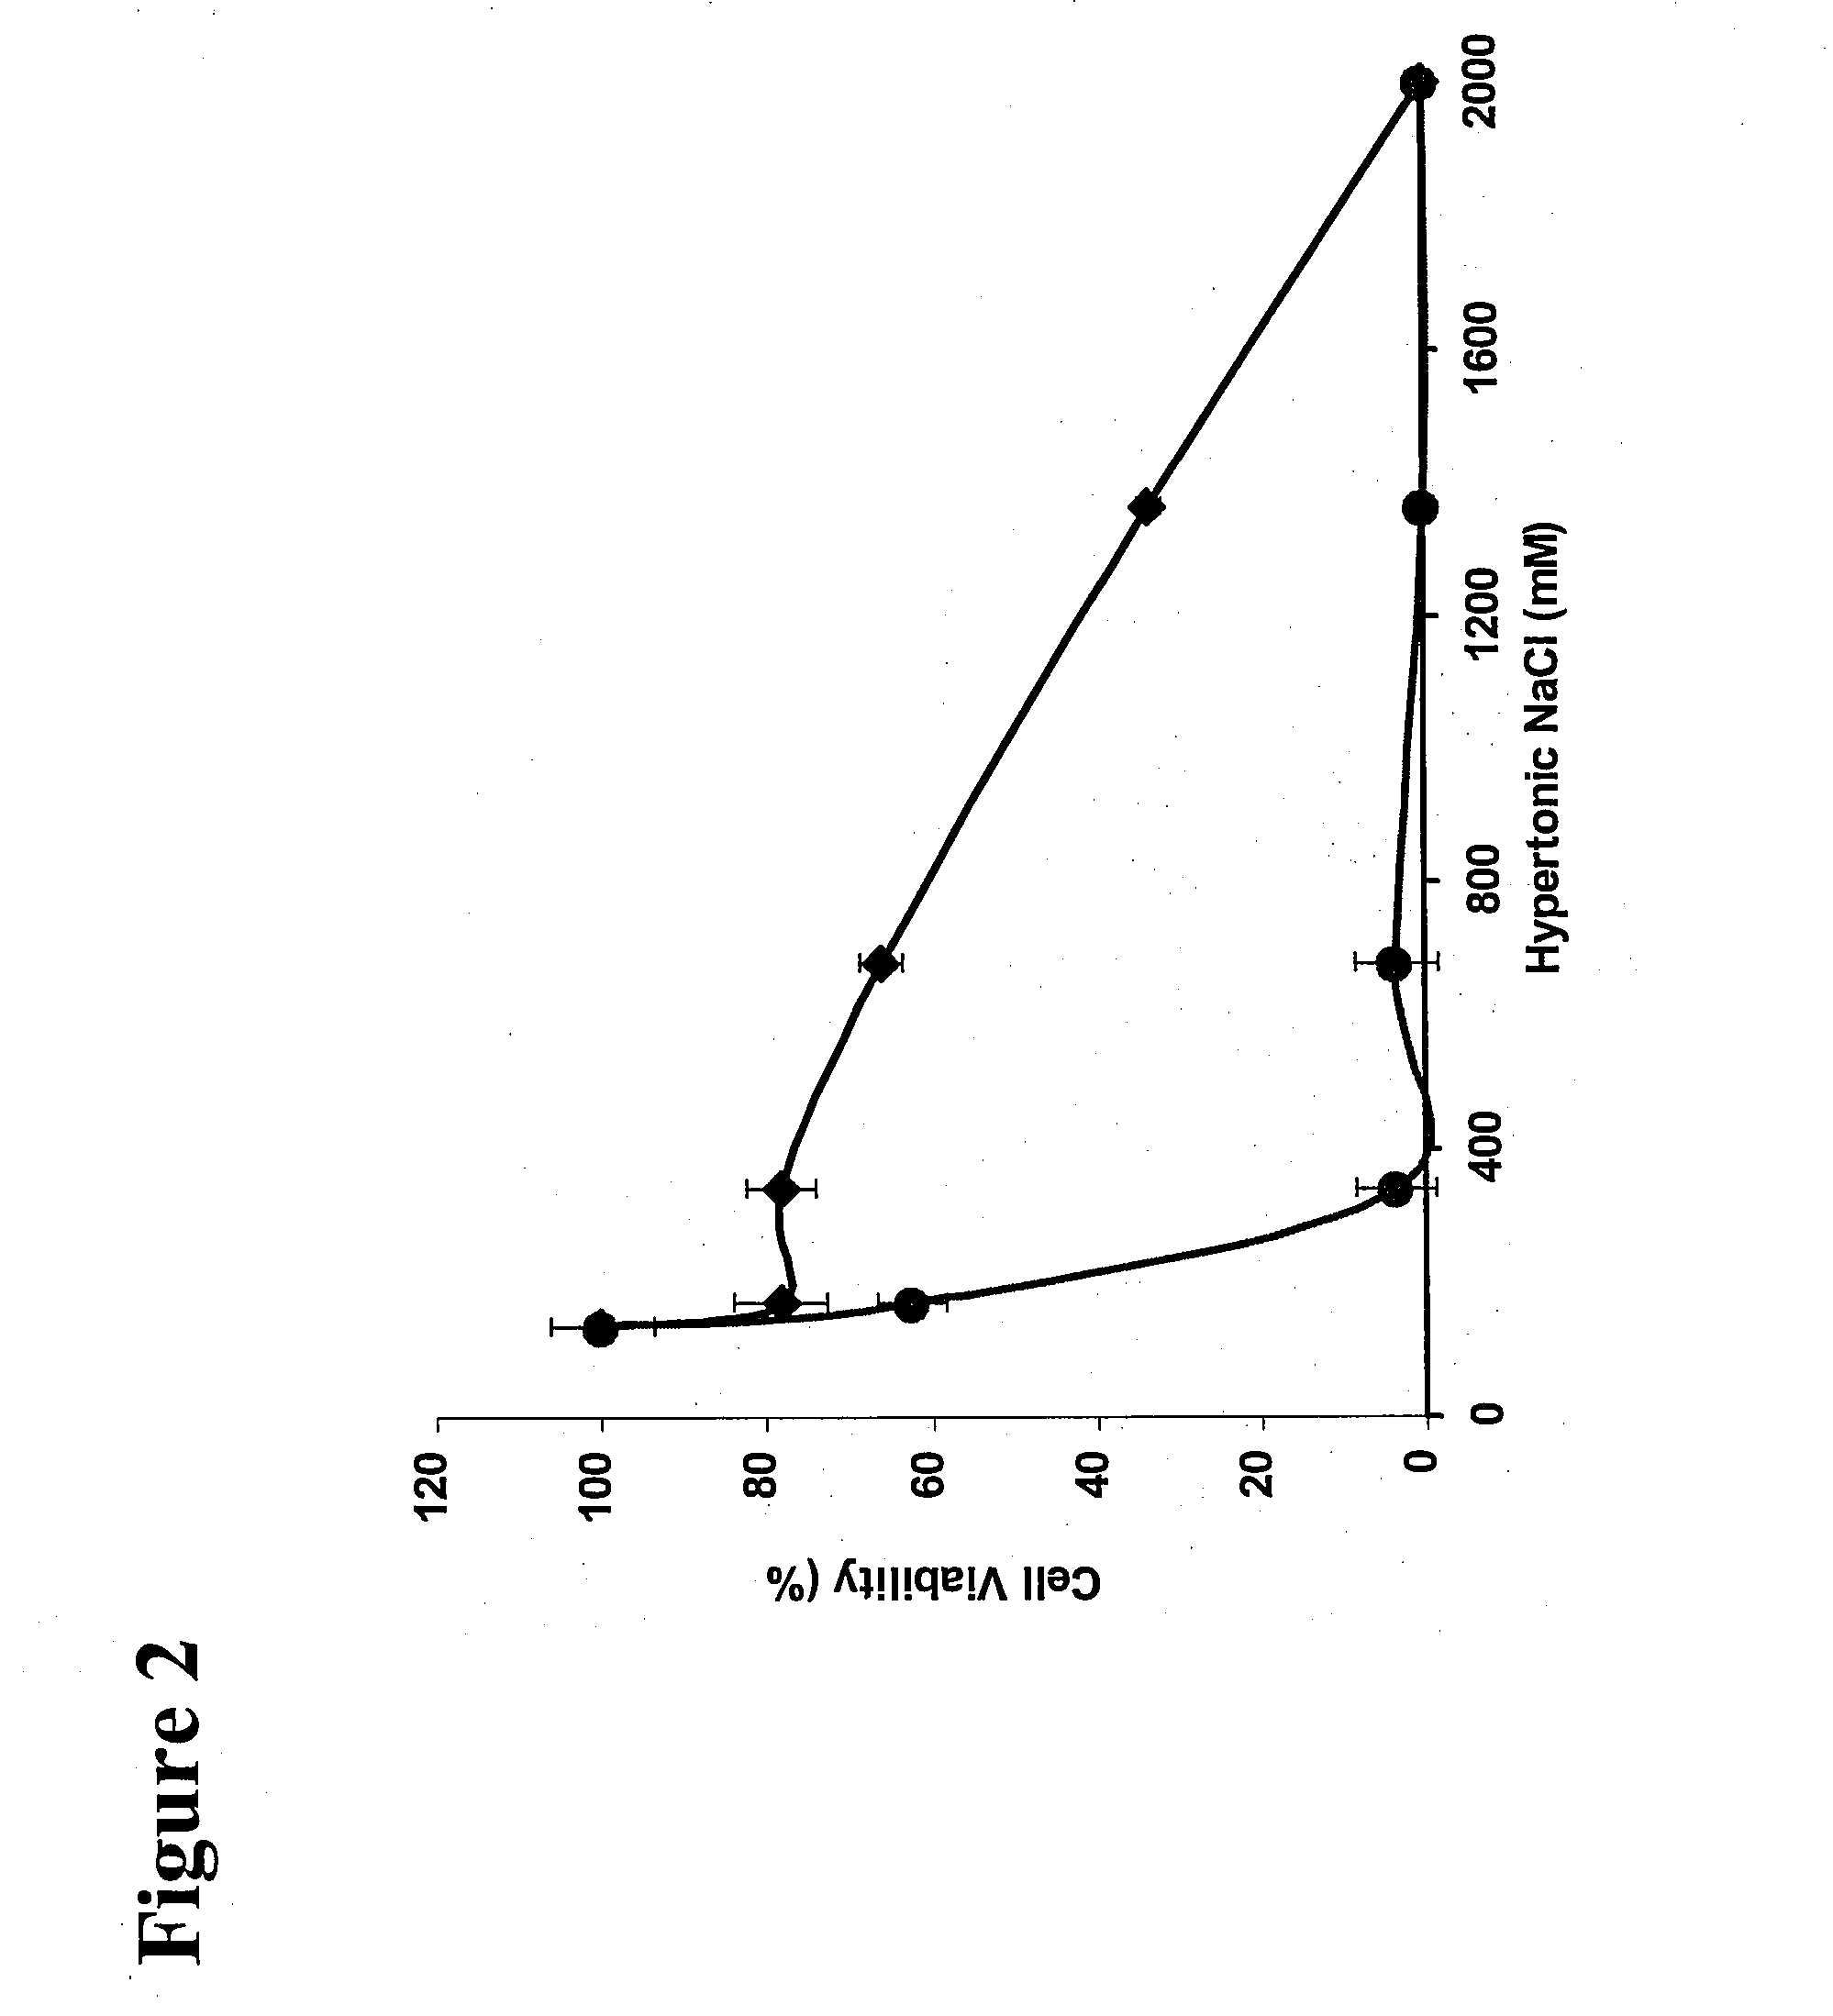
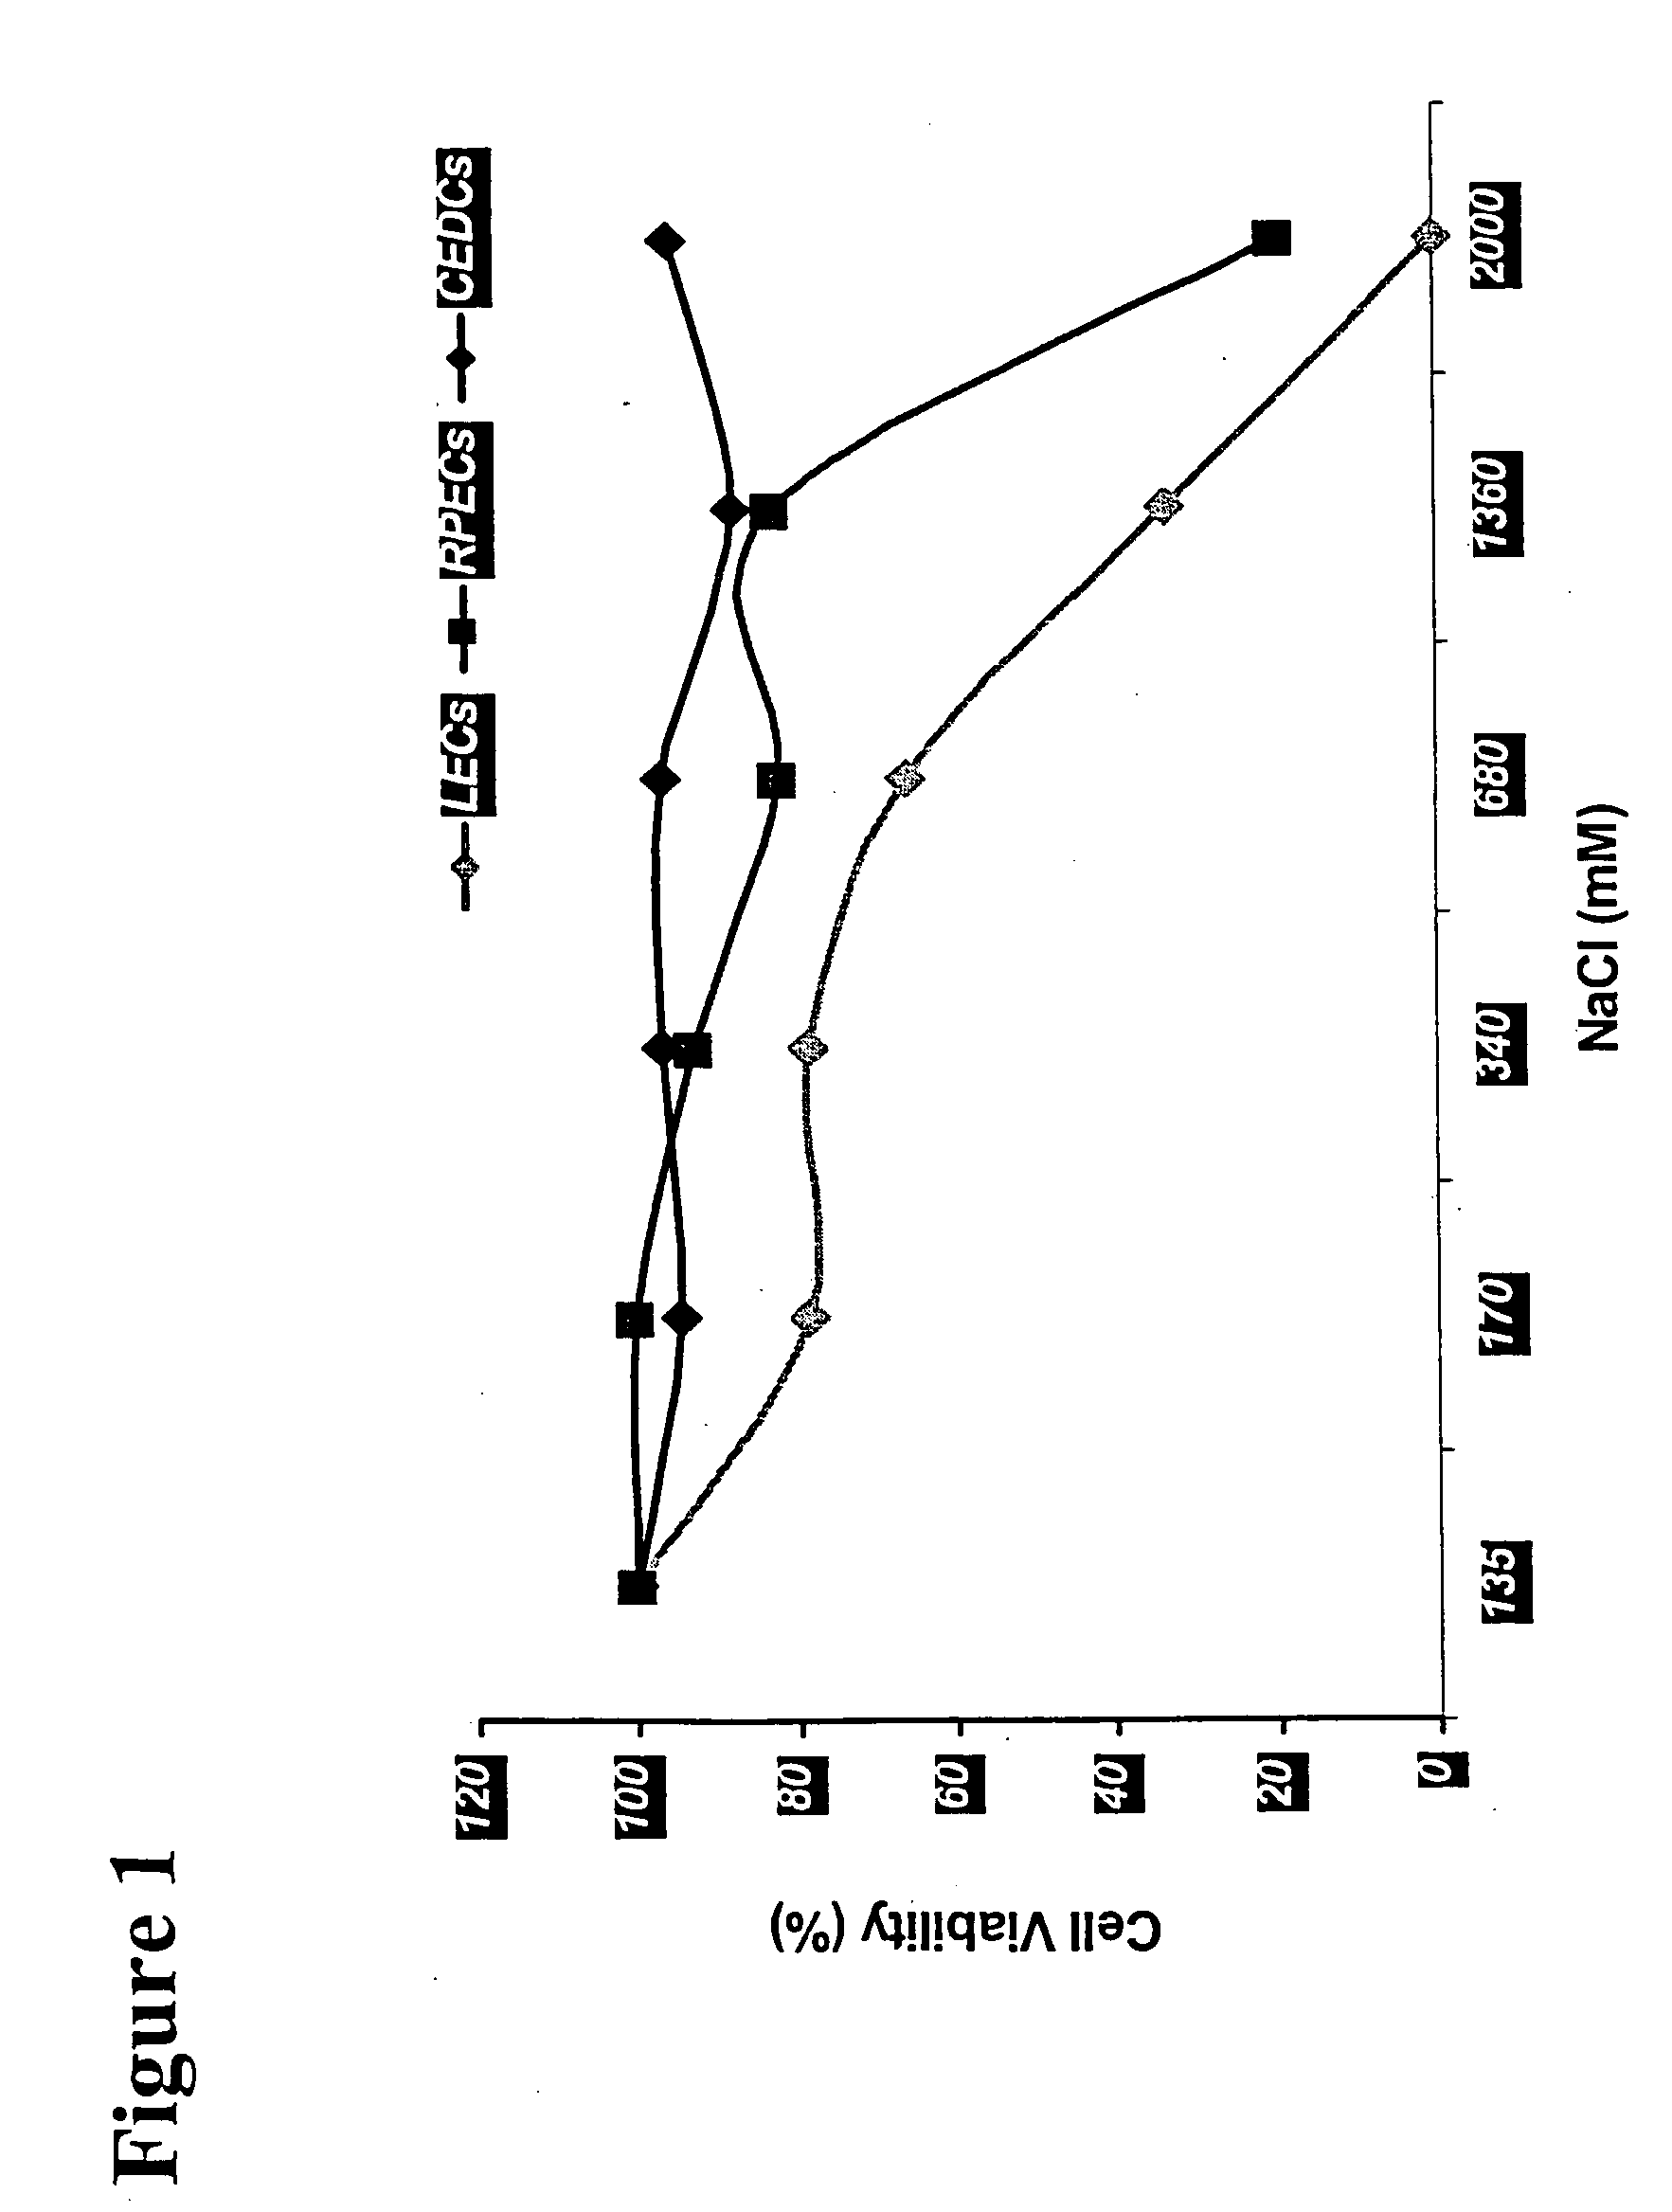
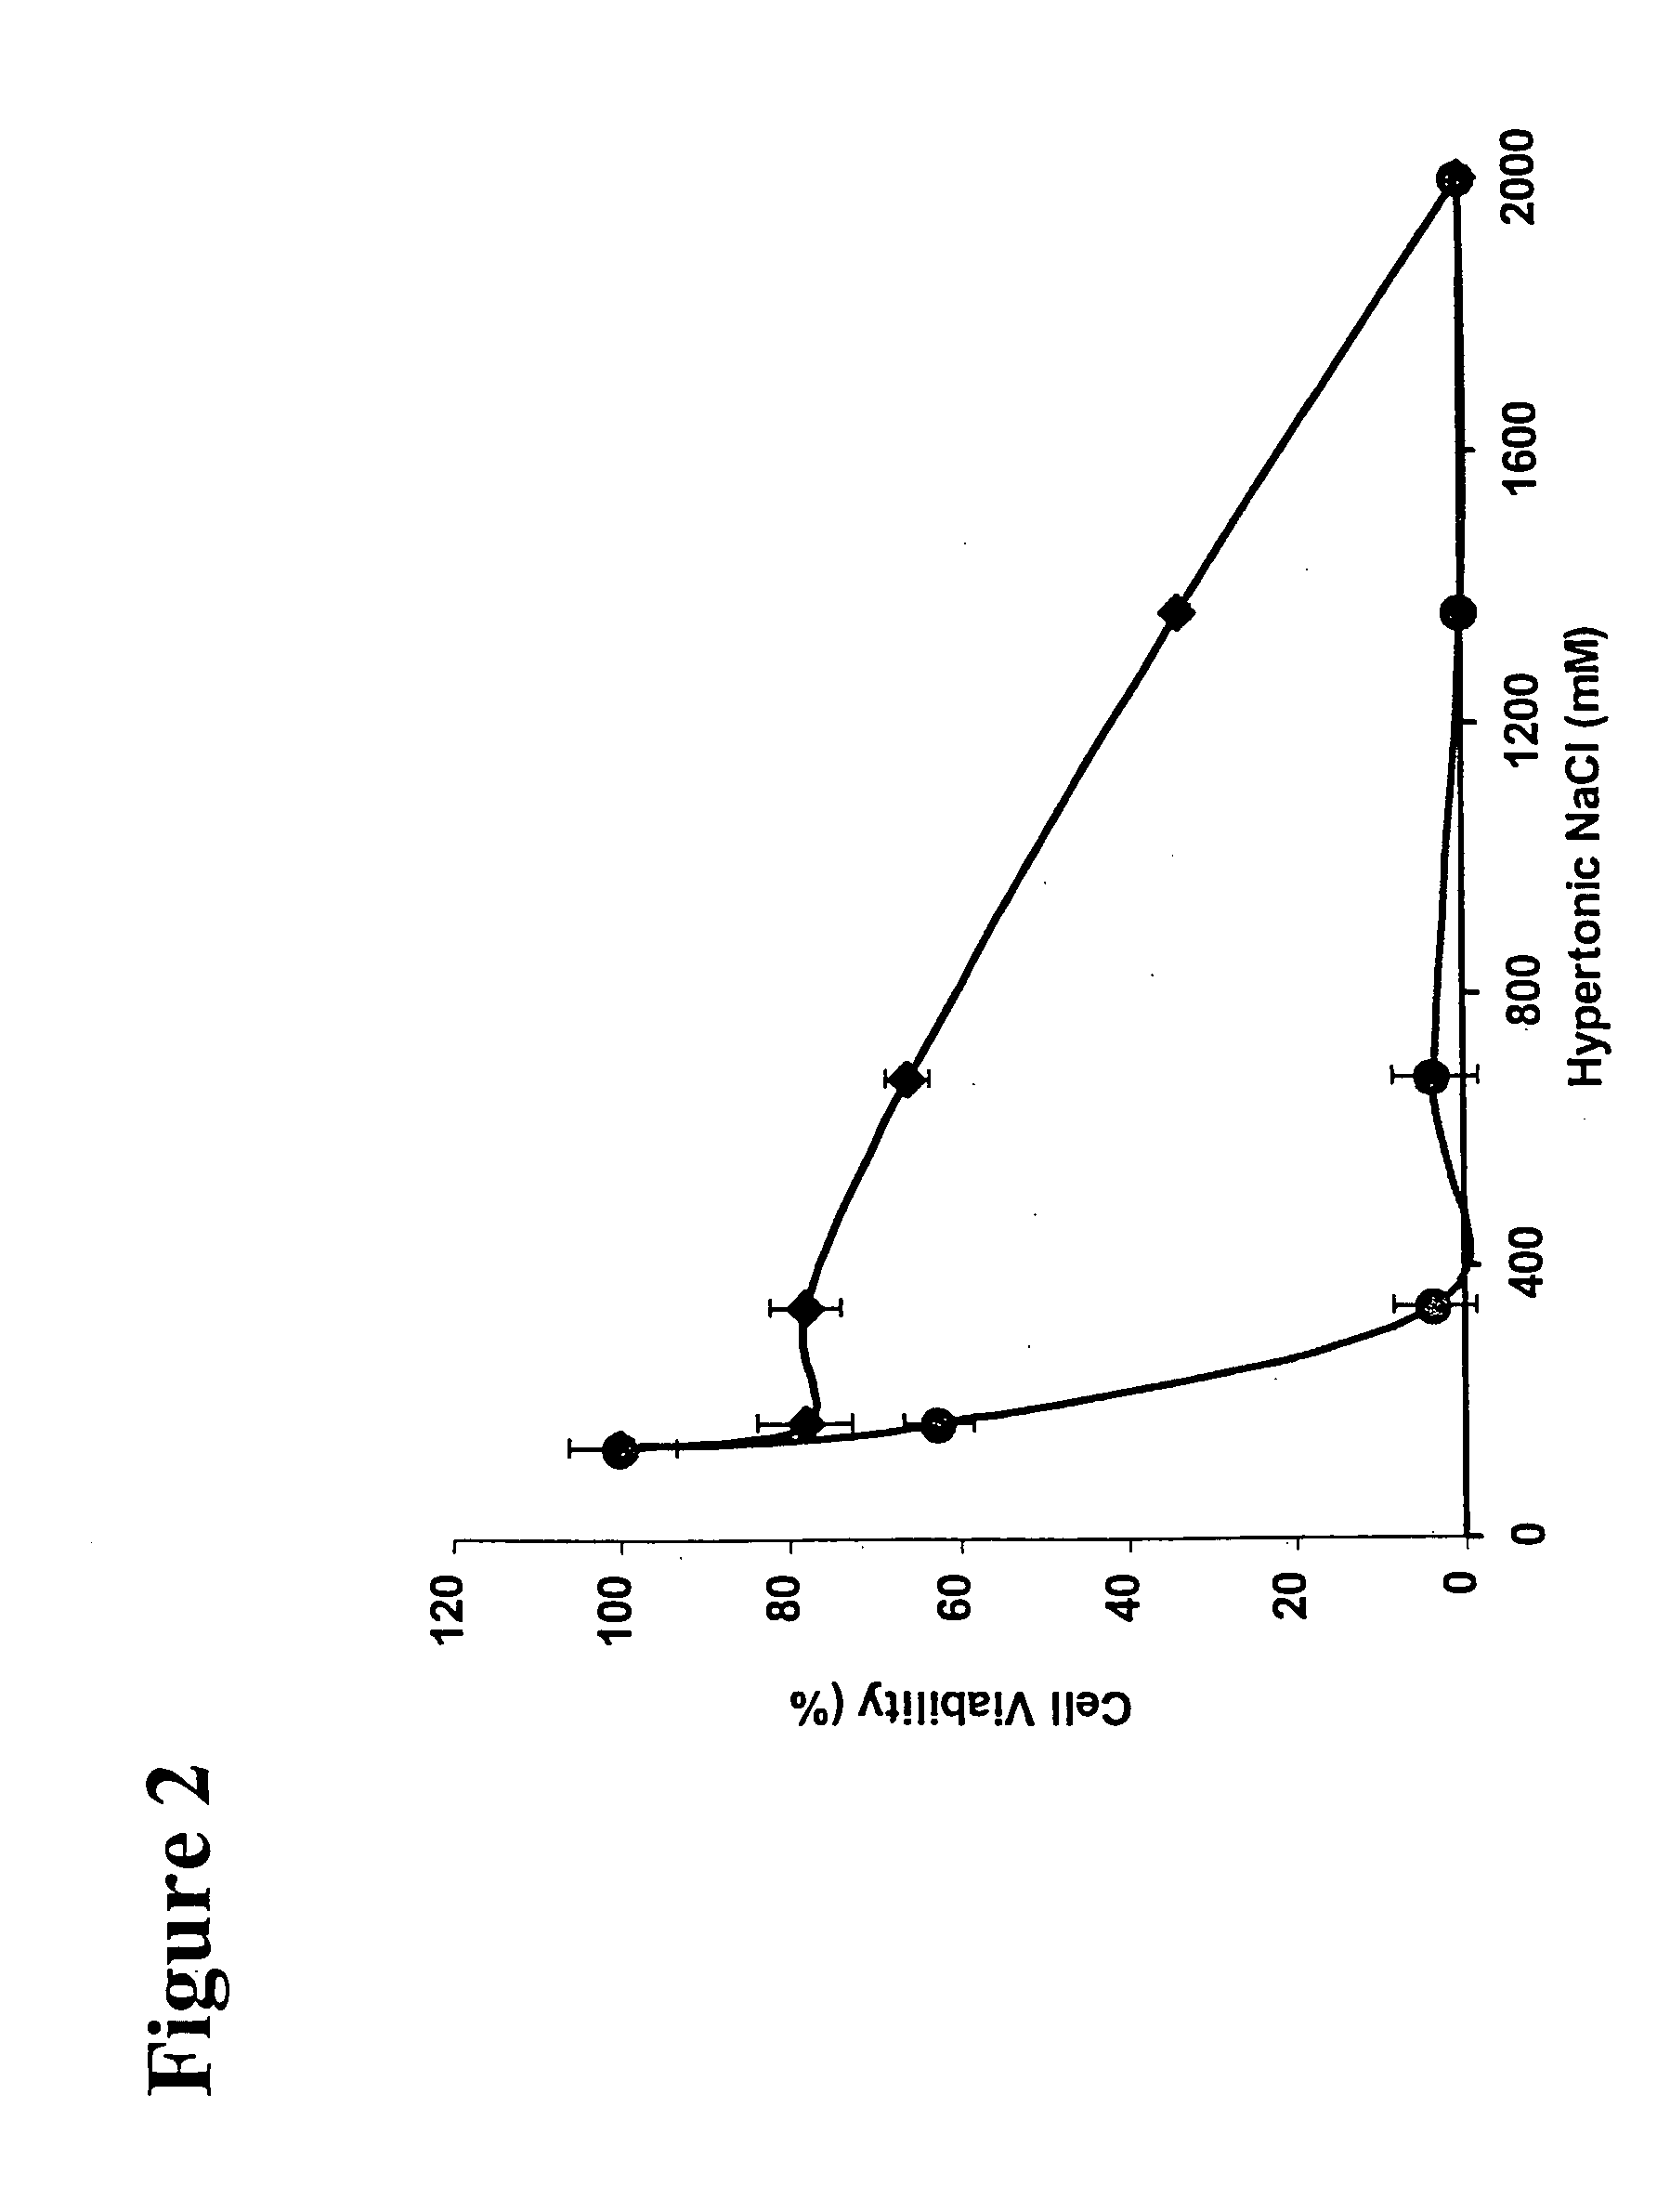
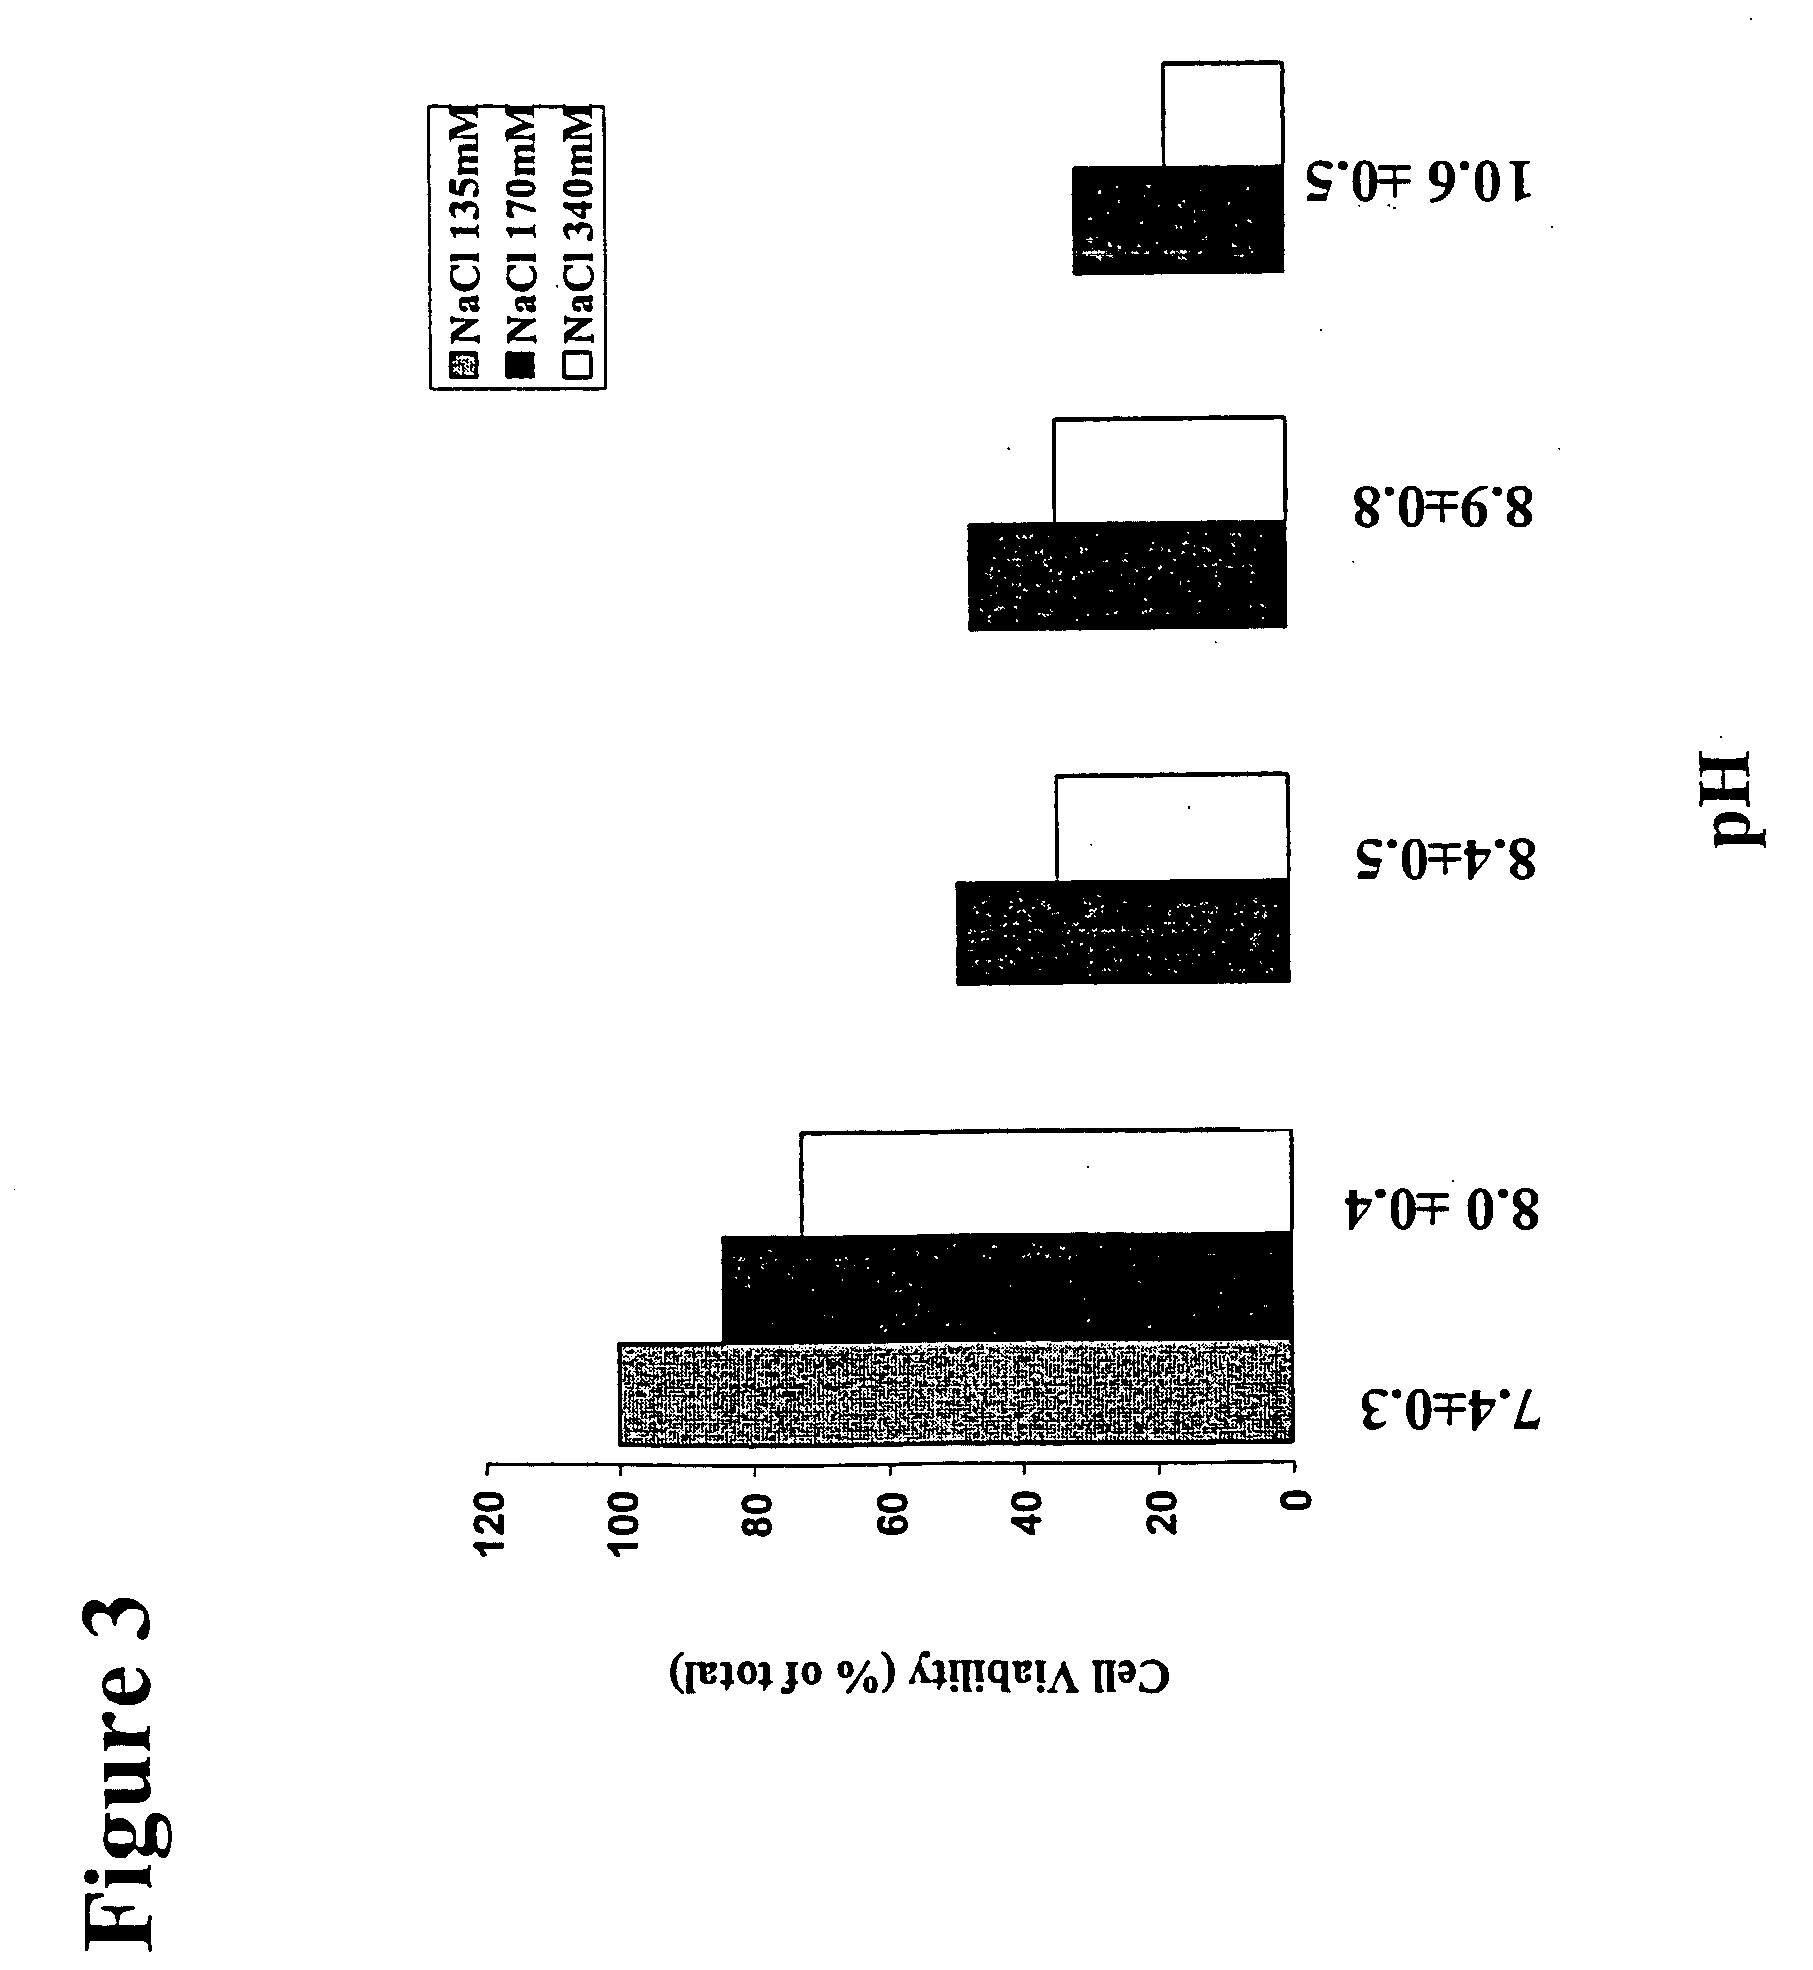
A treatment solution used to prevent posterior capsular opacification is applied or introduced into the lens capsular bag before, during, or after cataract surgery. The treatment solution comprises an ion transport mechanism interference agent, which either alone or in combination with other treatment agents such as an osmotic stress agent and an agent to establish a suitable pH, selectively induces detachment and / or death of lens epithelial cells such that posterior capsular opacification is prevented. While the ion transport mechanism interference agent is capable of interfering with the cellular mechanisms and cell ion distribution of a broad range of cells, a concentration of agent is selected such that the treatment solution interferes selectively with the cellular mechanisms of lens epithelial cells while leaving other ocular cells substantially unharmed. The treatment solution selectively induces cellular death and / or detachment of lens epithelial cells while other ocular cells and tissue remain substantially unharmed and without lengthy preoperative pre-treatment.
Owner:ABBOTT MEDICAL OPTICS INC
Biological reagents and methods for determining the mechanism in the generation of beta-amyloid peptide
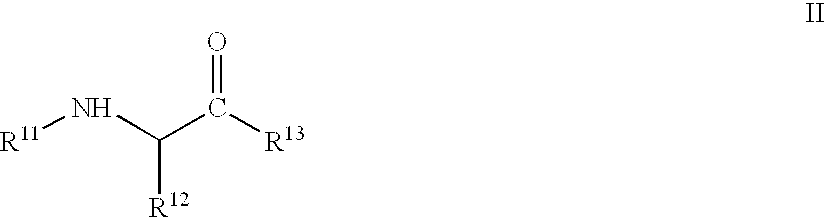
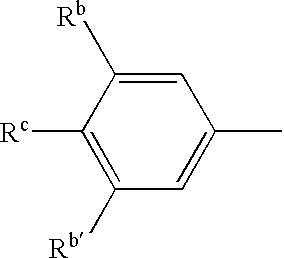
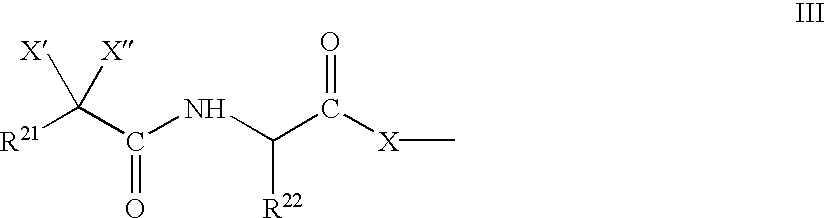
Disclosed are biological reagents which comprise compounds that inhibit beta-amyloid peptide release and / or its synthesis, and, accordingly, have utility in determining the cellular mechanism involved in the generation of beta-amyloid peptide.
Owner:ELI LILLY & CO +1
Method and system for treating obesity-linked diseases by oral administration of active receptor activator
InactiveCN108079317ASimplify treatment effect experimentsLow costCompounds screening/testingDiseaseNovel treatment method
The study is different from other studies in the prior art, and a biological method is used to explore the mechanism of action of AdipoRon on the treatment of type 2 diabetes. Liver cells are used asan experimental subject for construction of an experimental group blocking a P13 / Akt signaling pathway, then the AdipoRon acts, and expression of related carbohydrate genes of the liver cells is analyzed to investigate the cellular mechanism of the AdipoRon on the treatment of the type 2 diabetes. At present, the study is not reported at home and abroad. Almost all methods for treating the type 2diabetes require proper diet and exercise, and produce adverse effects such as hypoglycemia and weight gain, by oral administration of the AdipoRon, excess calorie intake can be safely reduced, and consequence caused by a sedentary lifestyle can be reduced, so that the AdipoRon provides a novel treatment method, a lot of money for purchase of db / db mice and double gene knockout mice can be saved.
Owner:WENZHOU MEDICAL UNIV
Treatment solution and method for preventing posterior capsular opacification by selectively inducing detachment and/or death of lens epithelial cells
InactiveUS7875270B2Great incidencePrevent PCOSenses disorderHydroxy compound active ingredientsIon distributionLens placode
A treatment solution used to prevent posterior capsular opacification is applied or introduced into the lens capsular bag before, during, or after cataract surgery. The treatment solution may also be applied to an intraocular lens prior to surgery. The treatment solution comprises an ion transport mechanism interference agent, which either alone or in combination with other treatment agents such as an osmotic stress agent and an agent to establish a suitable pH, selectively induces detachment and / or death of lens epithelial cells such that posterior capsular opacification is prevented. While the ion transport mechanism interference agent is capable of interfering with the cellular mechanisms and cell ion distribution of a broad range of cells, a concentration of agent is selected such that the treatment solution interferes selectively with the cellular mechanisms of lens epithelial cells while leaving other ocular cells substantially unharmed. The treatment solution selectively induces cellular death and / or detachment of lens epithelial cells while other ocular cells and tissue remain substantially unharmed and without lengthy preoperative pre-treatment.


Owner:ZHANG JIN JUN
Treatment solution and method for preventing posterior capsular opacification by selectively inducing detachment and/or death of lens epithelial cells
InactiveUS20050159410A1Prevent PCOEasy to disassembleSenses disorderHydroxy compound active ingredientsIon distributionCellular mechanism
A treatment solution used to prevent posterior capsular opacification is applied or introduced into the lens capsular bag before, during, or after cataract surgery. The treatment solution may also be applied to an intraocular lens prior to surgery. The treatment solution comprises an ion transport mechanism interference agent, which either alone or in combination with other treatment agents such as an osmotic stress agent and an agent to establish a suitable pH, selectively induces detachment and / or death of lens epithelial cells such that posterior capsular opacification is prevented. While the ion transport mechanism interference agent is capable of interfering with the cellular mechanisms and cell ion distribution of a broad range of cells, a concentration of agent is selected such that the treatment solution interferes selectively with the cellular mechanisms of lens epithelial cells while leaving other ocular cells substantially unharmed. The treatment solution selectively induces cellular death and / or detachment of lens epithelial cells while other ocular cells and tissue remain substantially unharmed and without lengthy preoperative pre-treatment.
Owner:ZHANG JIN JUN
C-glucosidic ellagitannin compounds for use for altering the supramolecular arrangement of actin and for the treatment of osteoporosis, cancer, bacterial infection and viral infection
InactiveUS20130324595A1Avoid spreadingEffective absorptionBiocideOrganic active ingredientsMetaboliteCellular mechanism
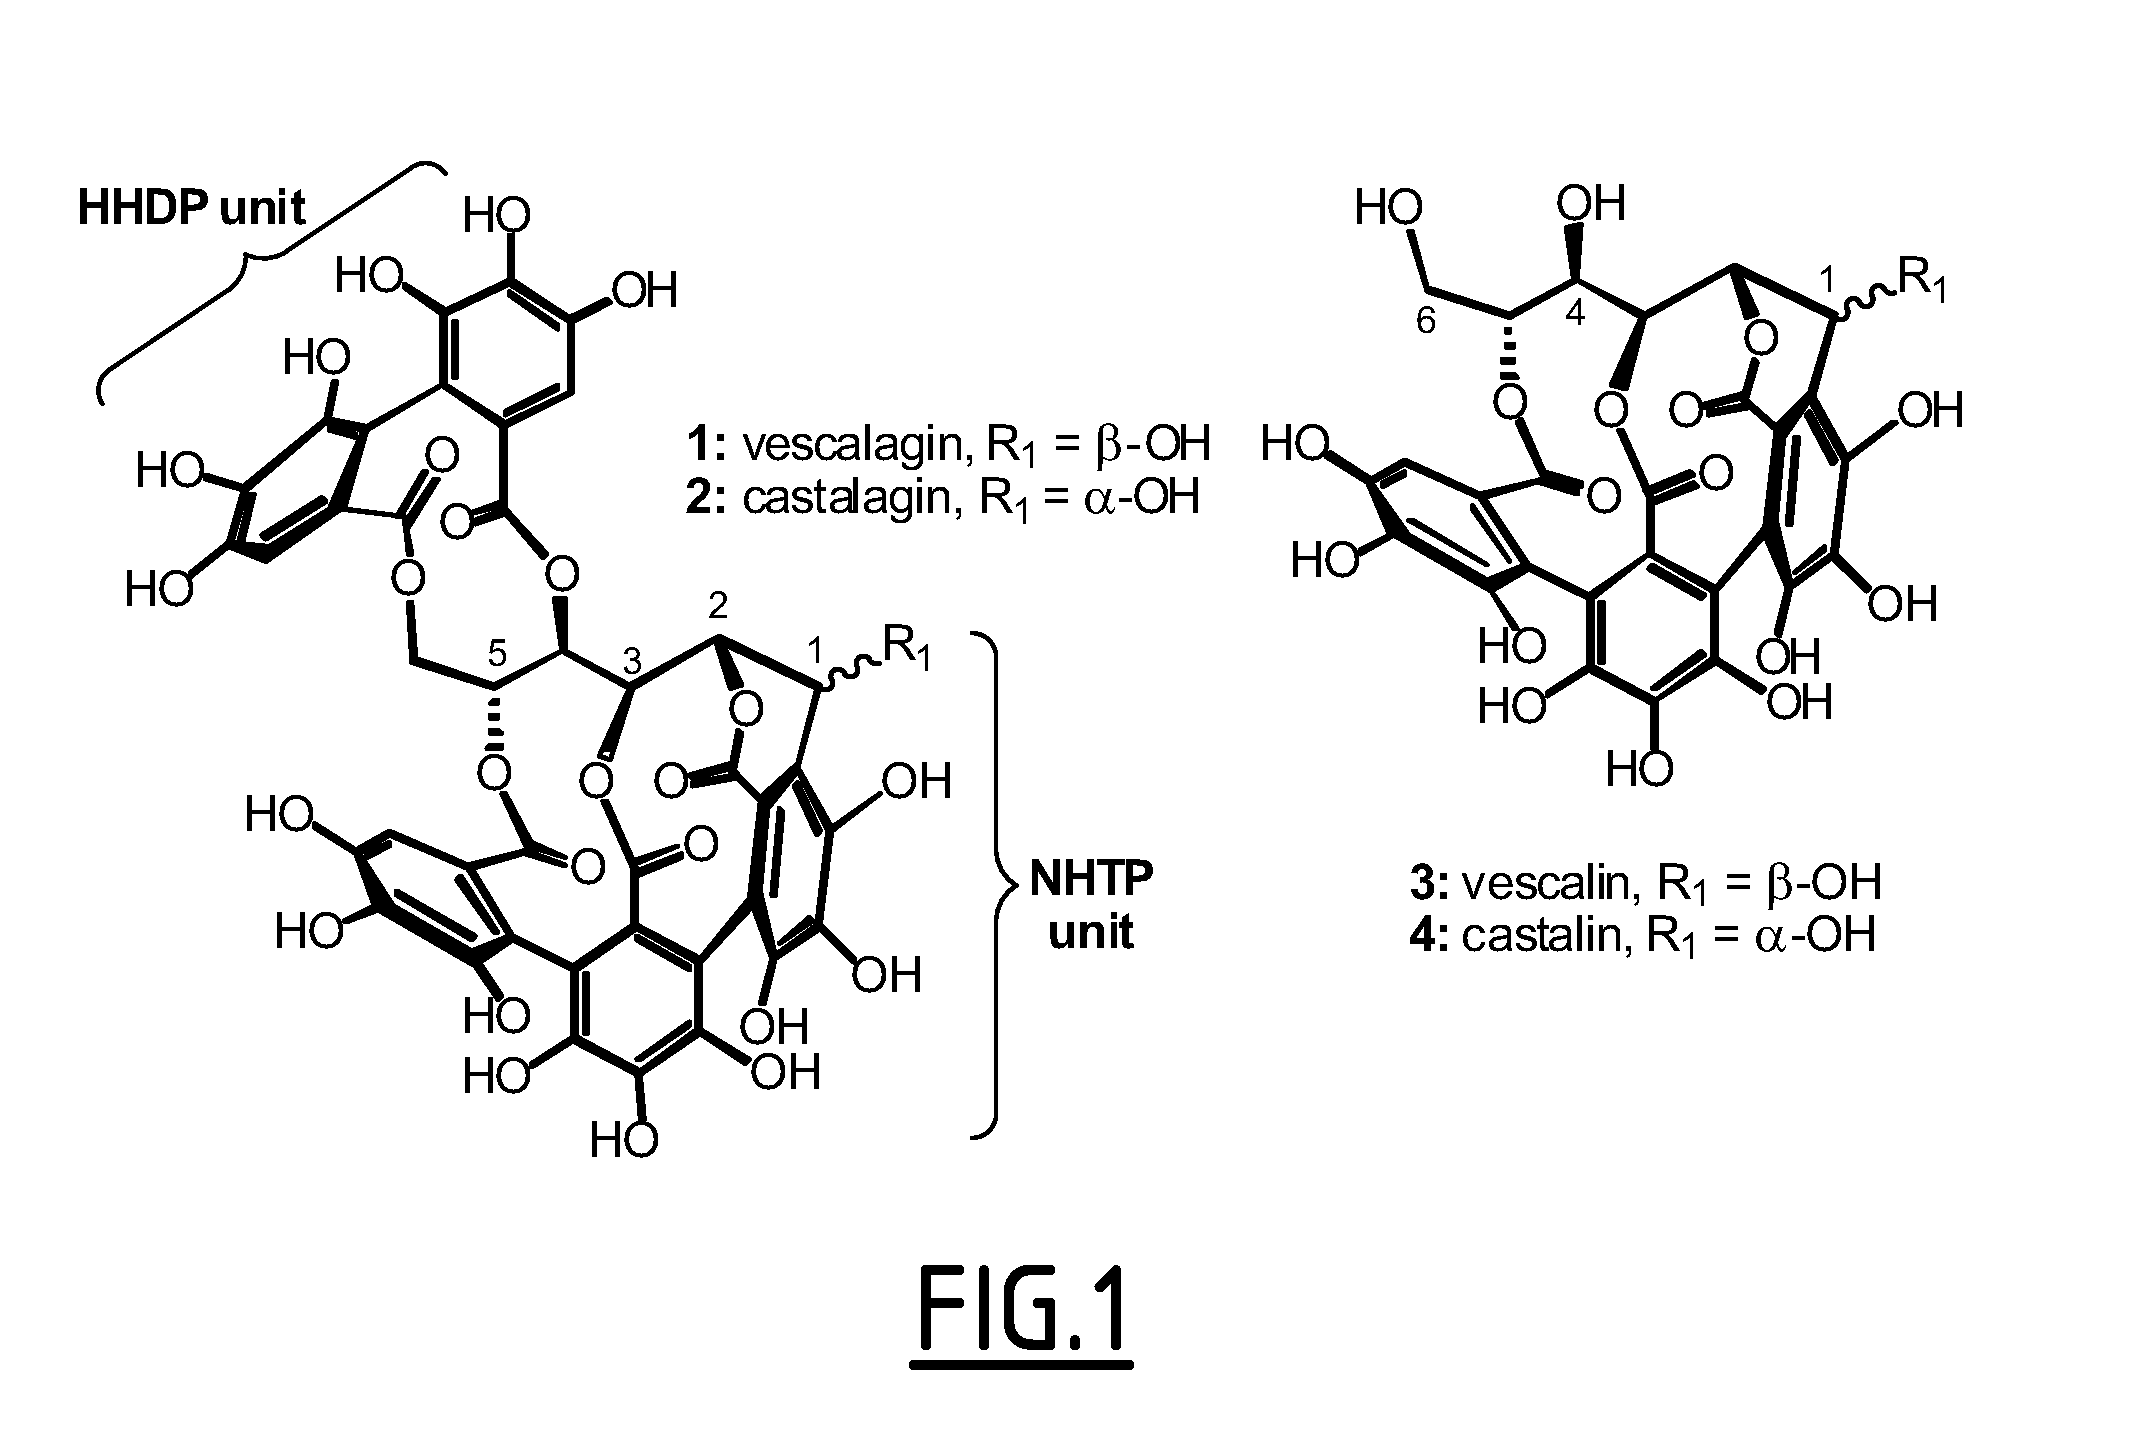
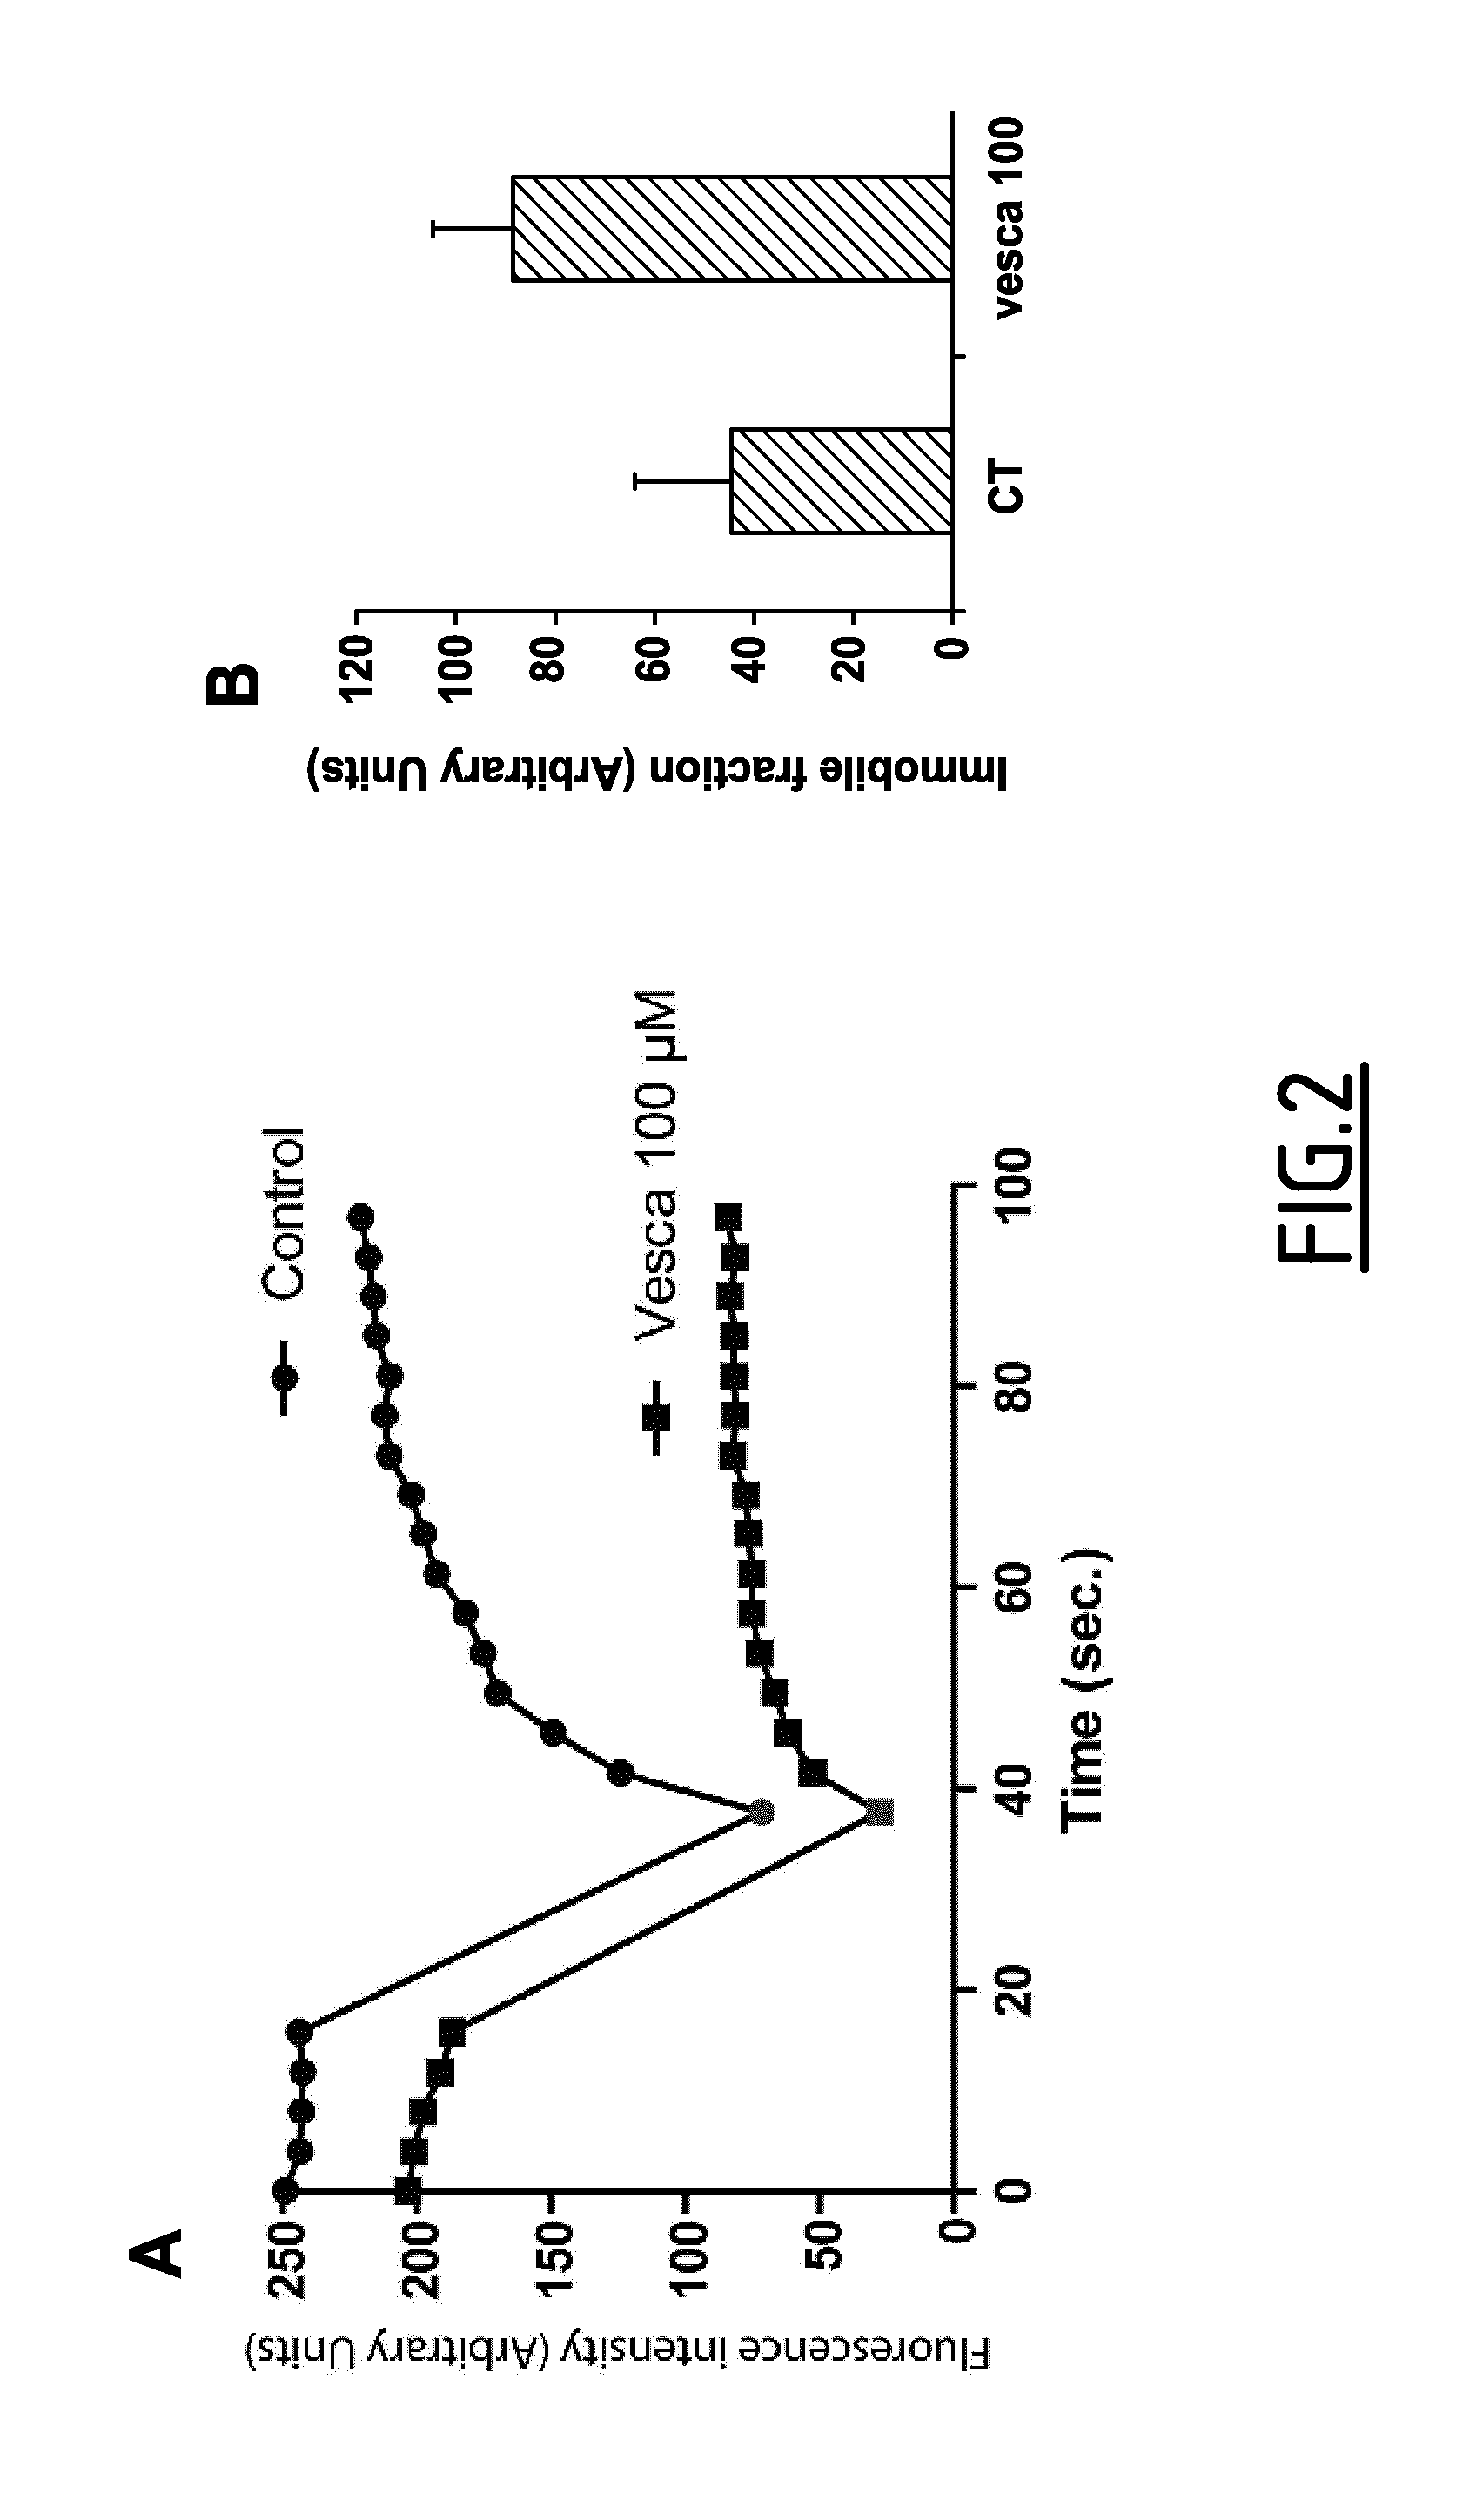
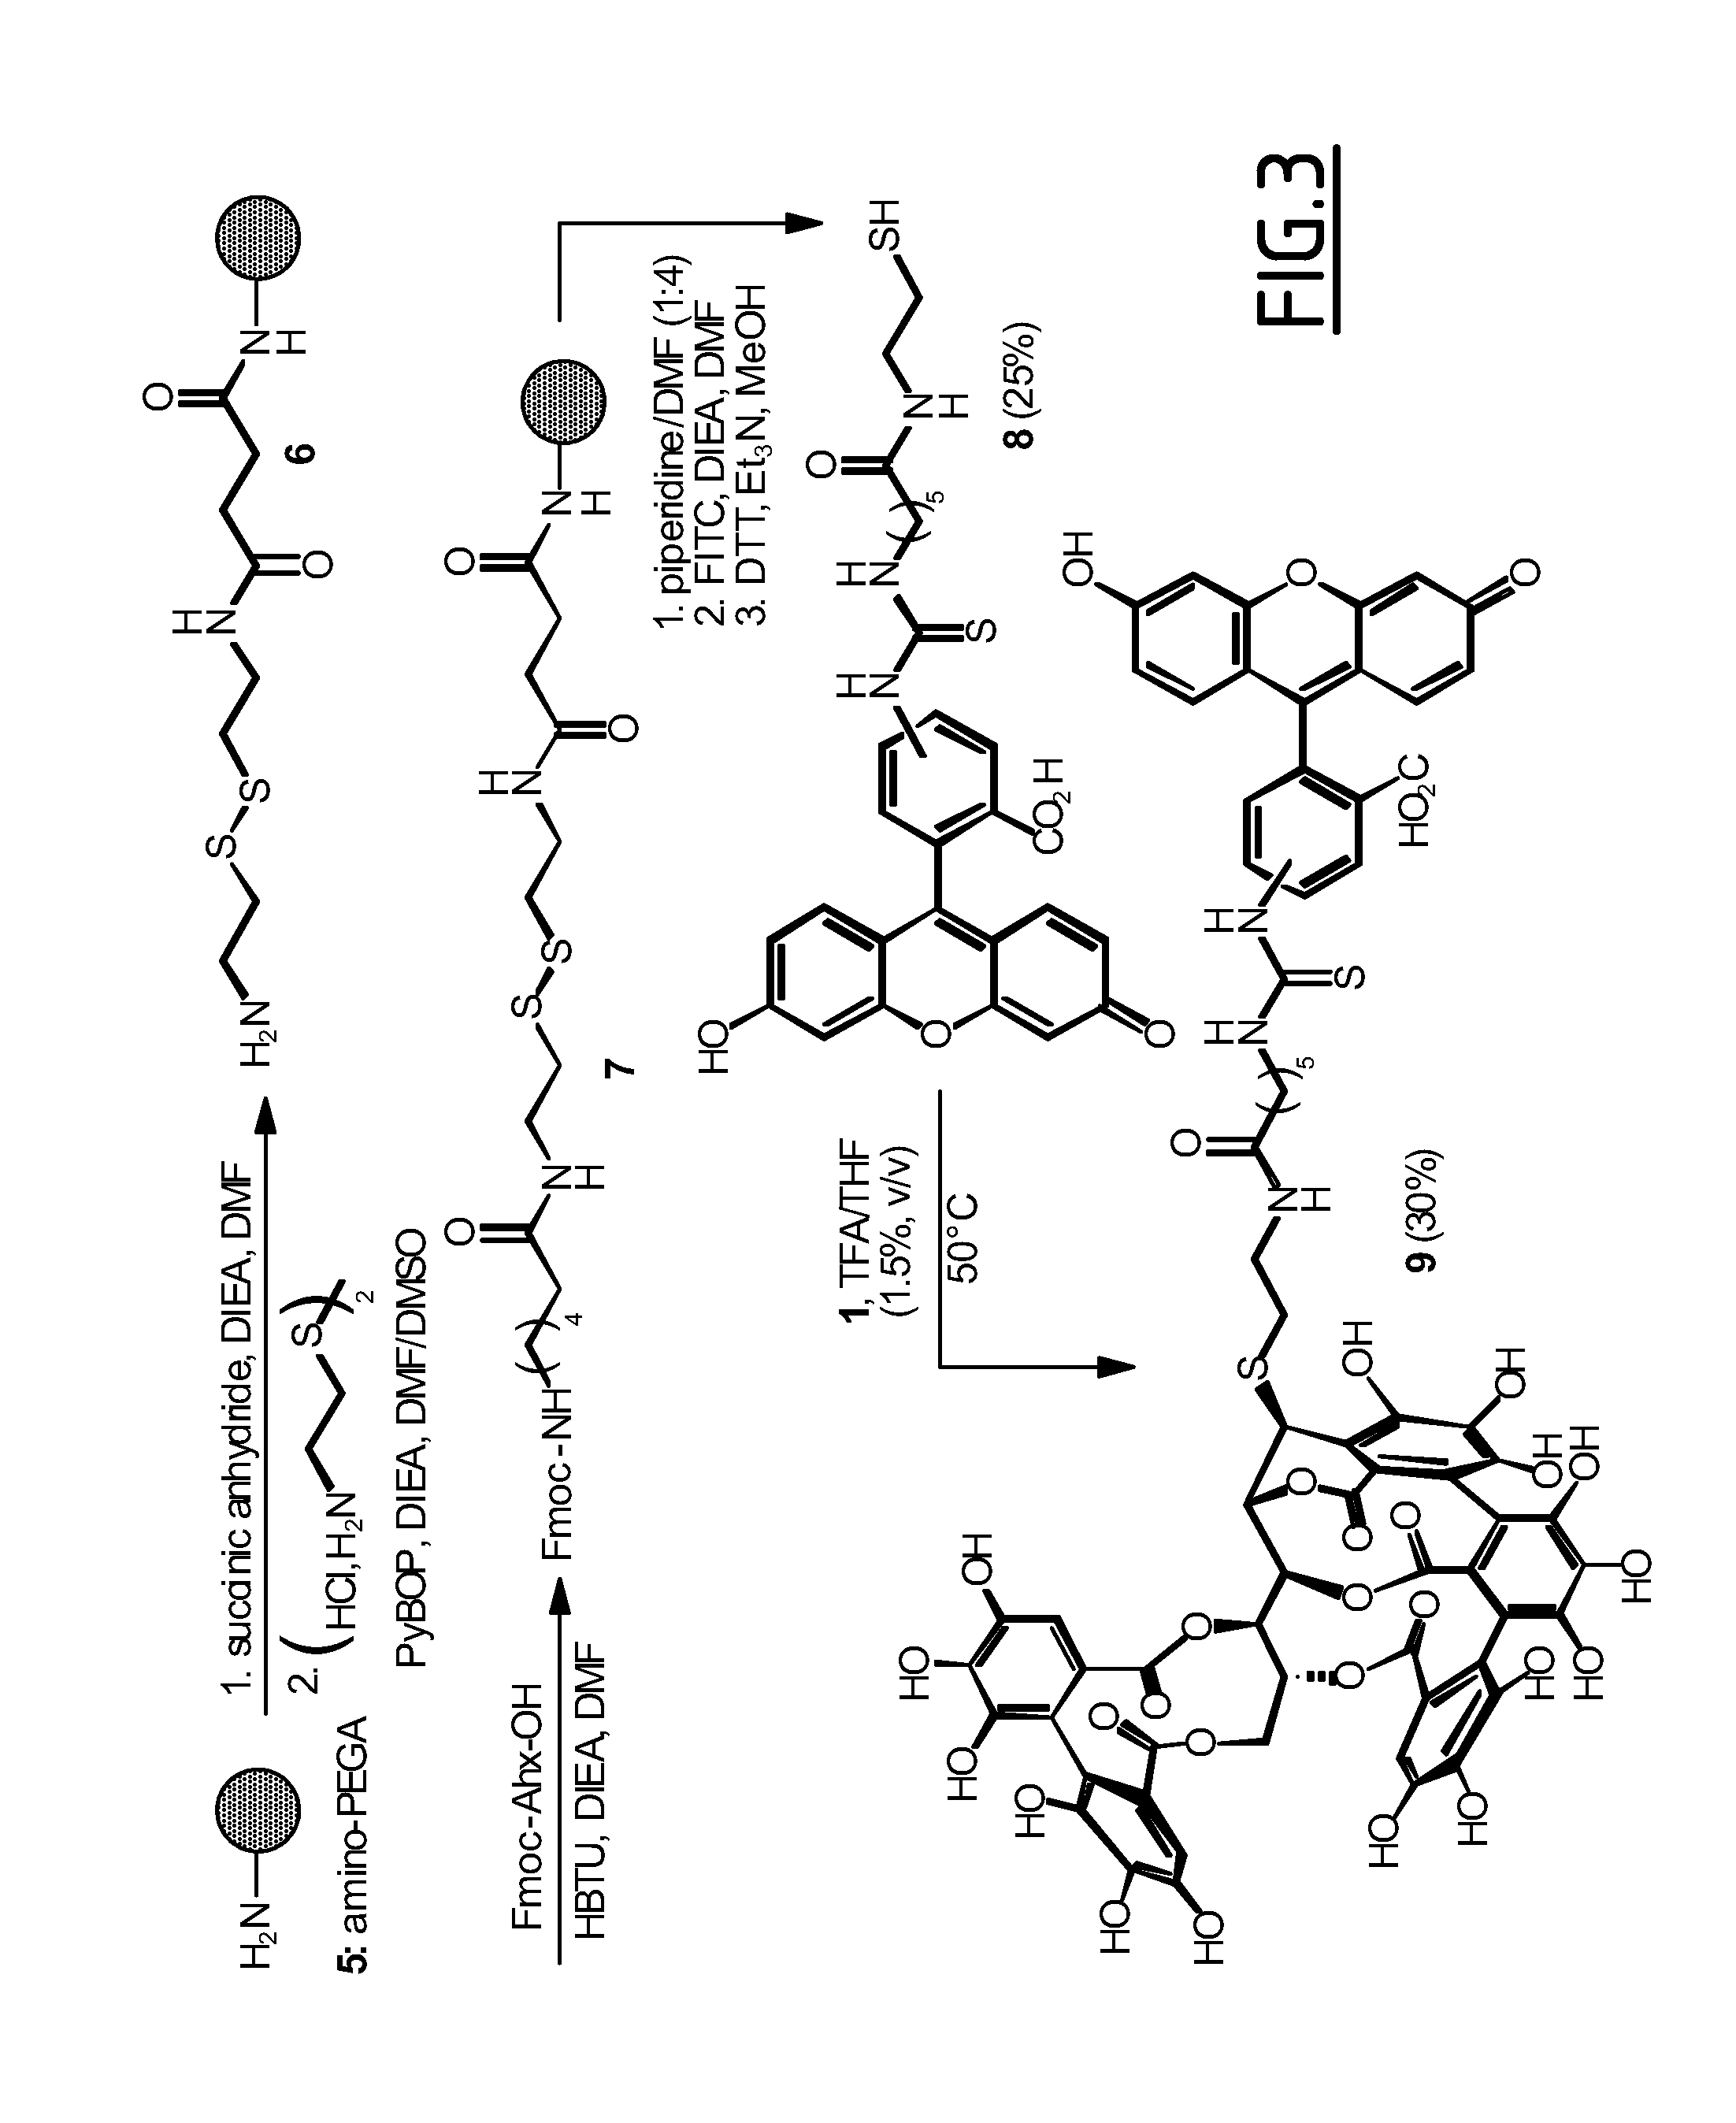
The present invention concerns a C-glucosidic ellagitannin compound or a metabolite thereof for use for altering the supramolecular arrangement of actin in an individual suffering from osteoporosis, cancer, bacterial infection, or viral infection. It also pertains to pharmaceutical compositions comprising a C-glucosidic ellagitannin compound and / or metabolites thereof and one or more physiologically acceptable carriers. It finally concerns a C-glucosidic ellagitannin compound or a metabolite thereof, optionally detectably labeled, for in vitro use as a tool for studying cellular mechanisms involving actin, or for detecting F-actin in a cell.
Owner:INST NAT DE LA SANTE & DE LA RECHERCHE MEDICALE (INSERM) +1
In vitro modelling of haematopoietic stem cell medullary nests: a tool for studying the regulation of haematopoiesis, evaluating the nesting potential of a haematopoietic graft and testing the pharmacotoxicology of medicaments
ActiveUS20140349312A1Improve the level ofCompound screeningApoptosis detectionCellular mechanismOsteocyte
The present invention relates to a culture support for cultivating hematopoietic stem cells (HSCs) and / or hematopoietic progenitors (HPs), comprising a calcium biomaterial, osteoclasts, endothelial cells and mesenchymatous stem cells (MSCs) and / or osteoblasts and / or adipocytes. The present invention also relates to a method for preparing such a culture support, and an in vitro HSC and / or HP cultivation method. The use of such a culture support for studying cellular mechanisms involved in hematopoiesis and / or differentiation of HSC / HPs and / or for studying the efficacy and / or the toxicity of a medicament candidate is also described.


Owner:ETAT FR MINIST DE LA DEFENSE SERVICE DE SANTE DES ARMEES +1
Conical surface dimensional space deformable honeycomb mechanism
The invention discloses a conical surface dimensional space deformable honeycomb mechanism, and belongs to the technical field of aerospace. The conical surface dimensional space deformable honeycomb mechanism comprises an annular space honeycomb mechanism and a driving system, and the annular space honeycomb mechanism is deformed along a conical surface with a fixed taper by controlling the driving system. The annular space honeycomb mechanism comprises a plurality of honeycomb units which are of concave hexagonal structures, each honeycomb unit comprises two beams with different lengths and four ribs with the same length and structure, the beams are connected through hinges, and the ribs are connected through hinges; the driving system comprises a main body frame, a motor, a synchronous belt wheel, a trapezoidal lead screw and a clamping jaw. The annular space honeycomb mechanism is designed, and fitting of a target conical surface can be achieved by reasonably designing the sizes of the rod pieces in the honeycomb units; meanwhile, a driving system of the honeycomb mechanism is designed, and the honeycomb mechanism can deform along the conical surface with the fixed taper by controlling the driving system.

Owner:HARBIN INST OF TECH
Methods for reduction of adipose tissue mass
InactiveUS20080200422A1Increase glucose clearanceFaster clearance of glucoseBiocidePeptide/protein ingredientsCellular mechanismAgonist
The present disclosure relates to diets, compounds, e.g., GCN2 agonists and methods that selectively reduce adipose tissue mass relative to the mass of other tissue types and increase insulin sensitivity. Another aspect of the disclosure relates to methods for identifying GCN2 agonists that will decrease the activity and / or expression of one or more of adipogenic genes thereby selectively inhibiting the cellular mechanisms that lead to fat production. Such agonists have the effect of reducing adipose tissue mass in an individual.


Owner:PENN STATE RES FOUND
Cell bionic nanoparticles as well as construction method and application thereof
ActiveCN119139348AReduce immune response levelsGreat clinical valueSenses disorderPowder deliveryInflammatory factorsAutoimmune condition
The invention belongs to the technical field of cell bionic nano-drugs, and particularly discloses a cell bionic nano-particle as well as a construction method and application thereof. And performing simple ultrasonic fusion on the target cell membrane and the hydrophobic nano-core to obtain the cell bionic nano-particles. The bionic nano-cell can effectively inherit and simulate functional protein on the surface of a source cell membrane, systematically replace functions of the source cell in physiological and pathological processes, such as inflammatory factor adsorption, migration factor adsorption and the like, interfere and inhibit the disease process from the cellular mechanism, regulate and control cell composition and immune microenvironment of a focus part, and improve the immune function of the source cell membrane. The medicine does not need to be additionally carried. Aiming at the related pathogenesis of immune tolerance deficiency, the invention innovatively provides a therapeutic strategy for constructing immune tolerance. The homology and inherent immunosuppressive ability of tumor cells to the focus part of the autoimmune disease are reversely used, immune tolerance of the focus part based on immune checkpoints is reconstructed, meanwhile, target cells are replaced to adsorb autoimmune antibodies, and the immune response level is reduced.

Owner:KUNMING MEDICAL UNIVERSITY
Pseudocomplementary Oligonucleotides for Targeted Gene Therapy
ActiveUS20110086905A1Increase percentageIncrease flexibilitySugar derivativesOther foreign material introduction processesCellular mechanismDouble stranded
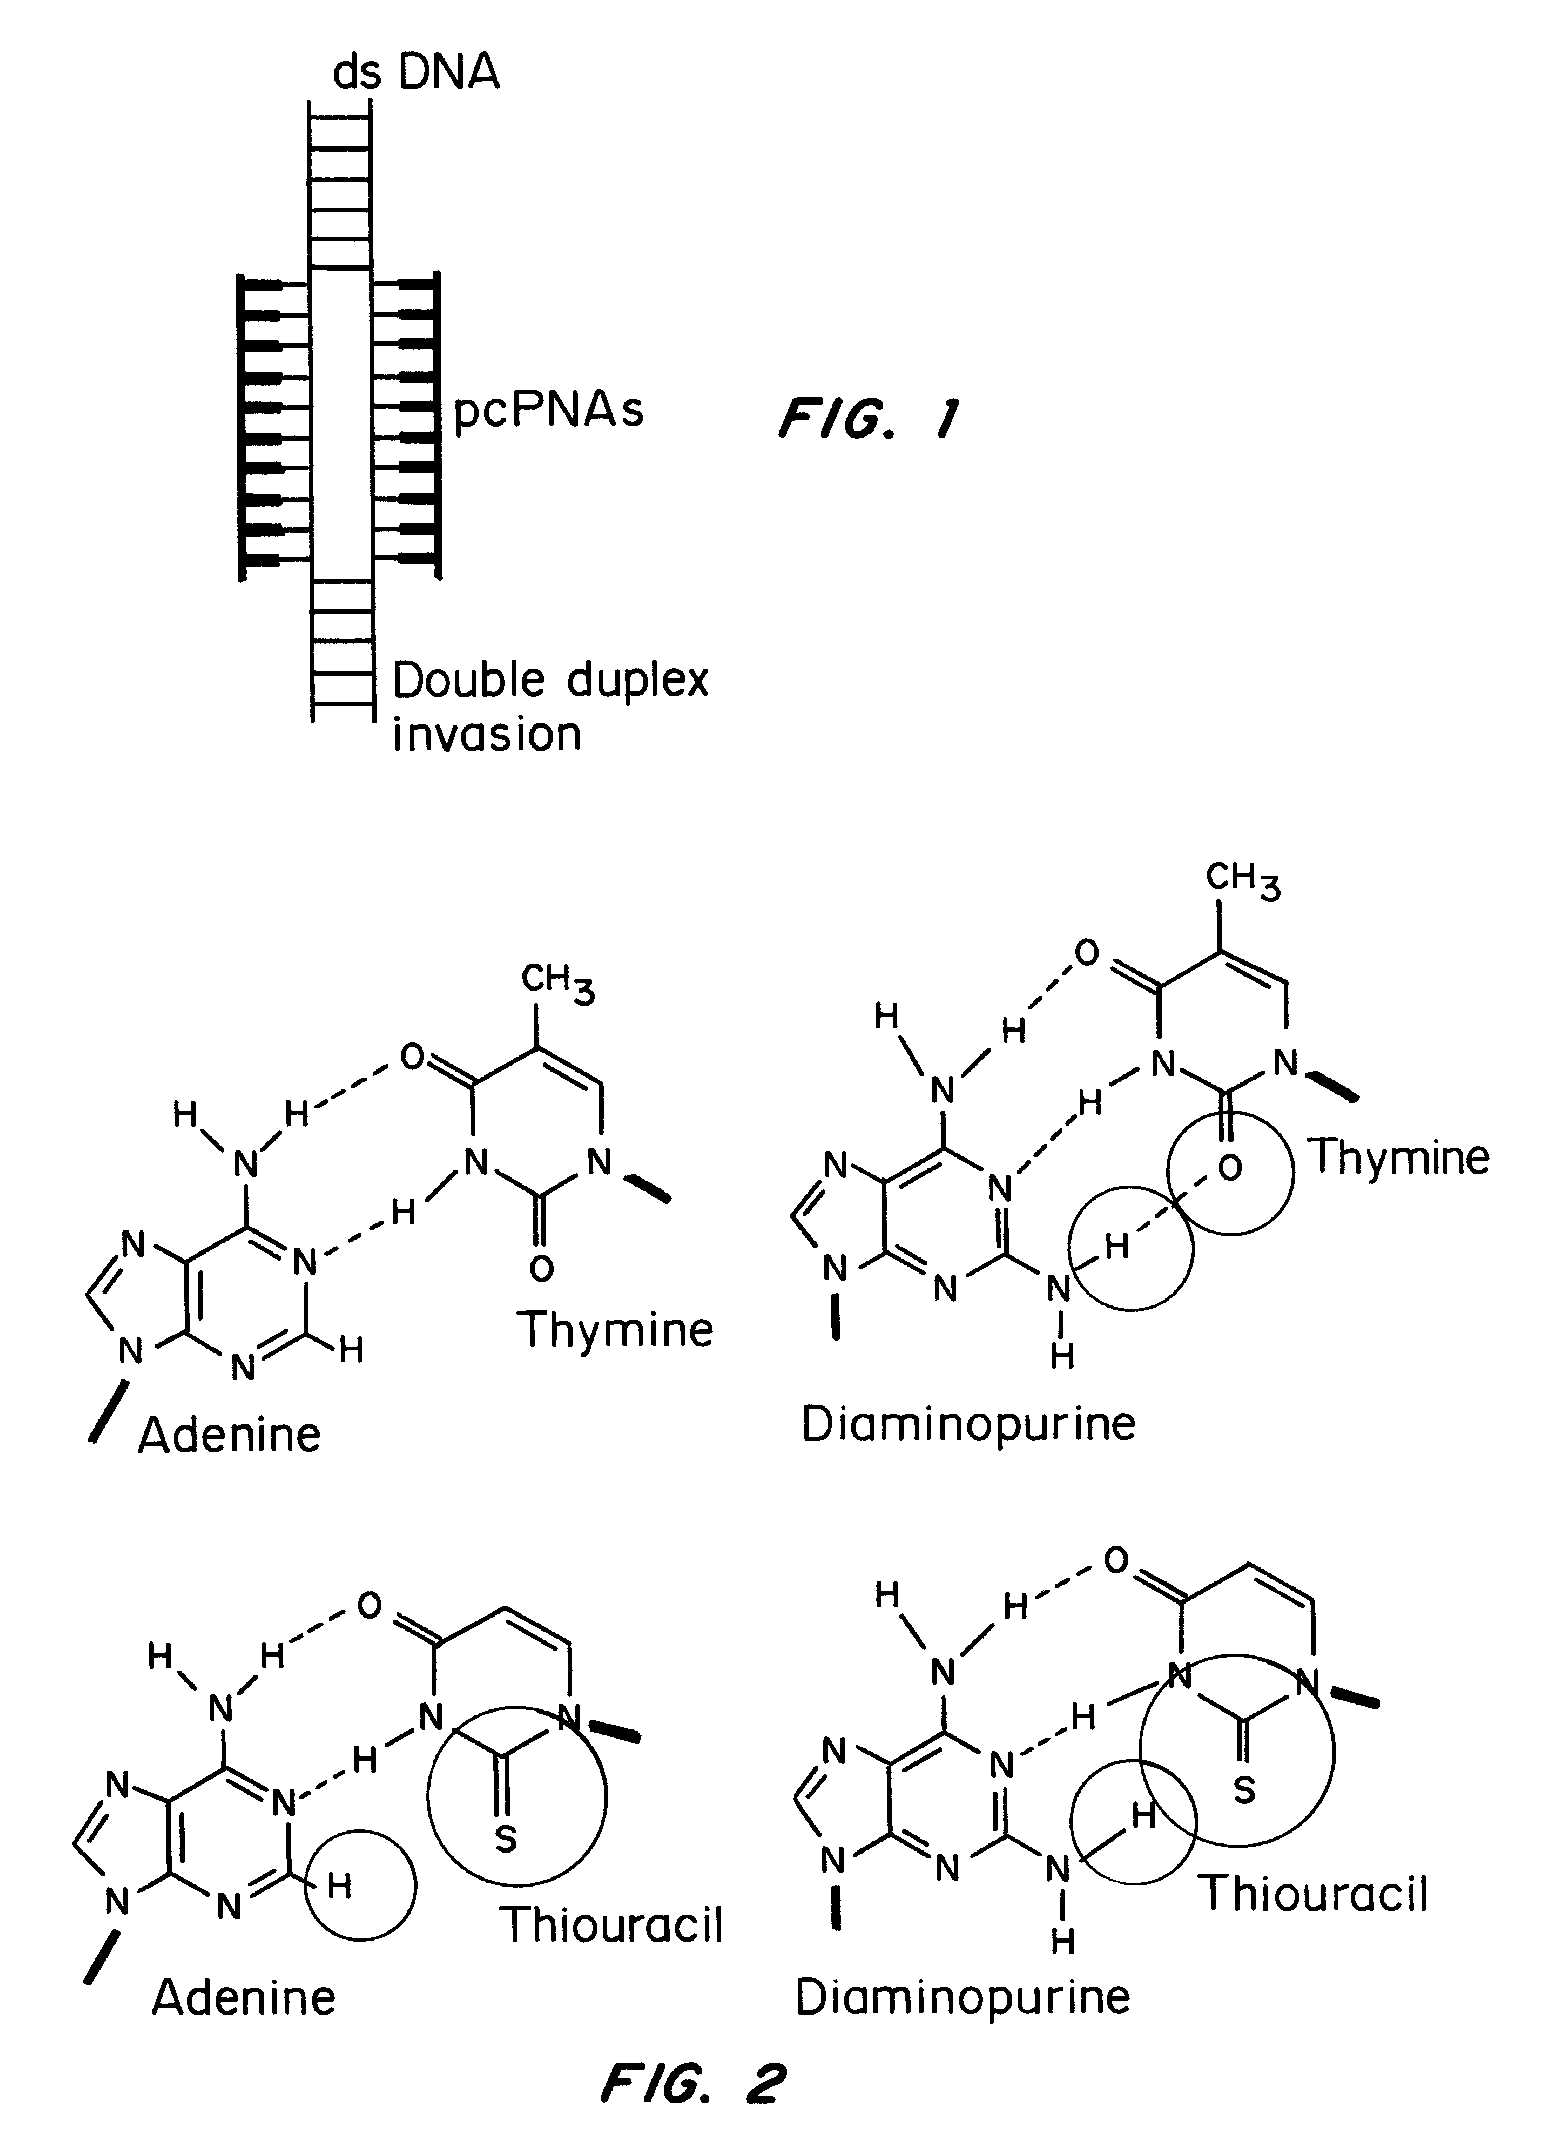
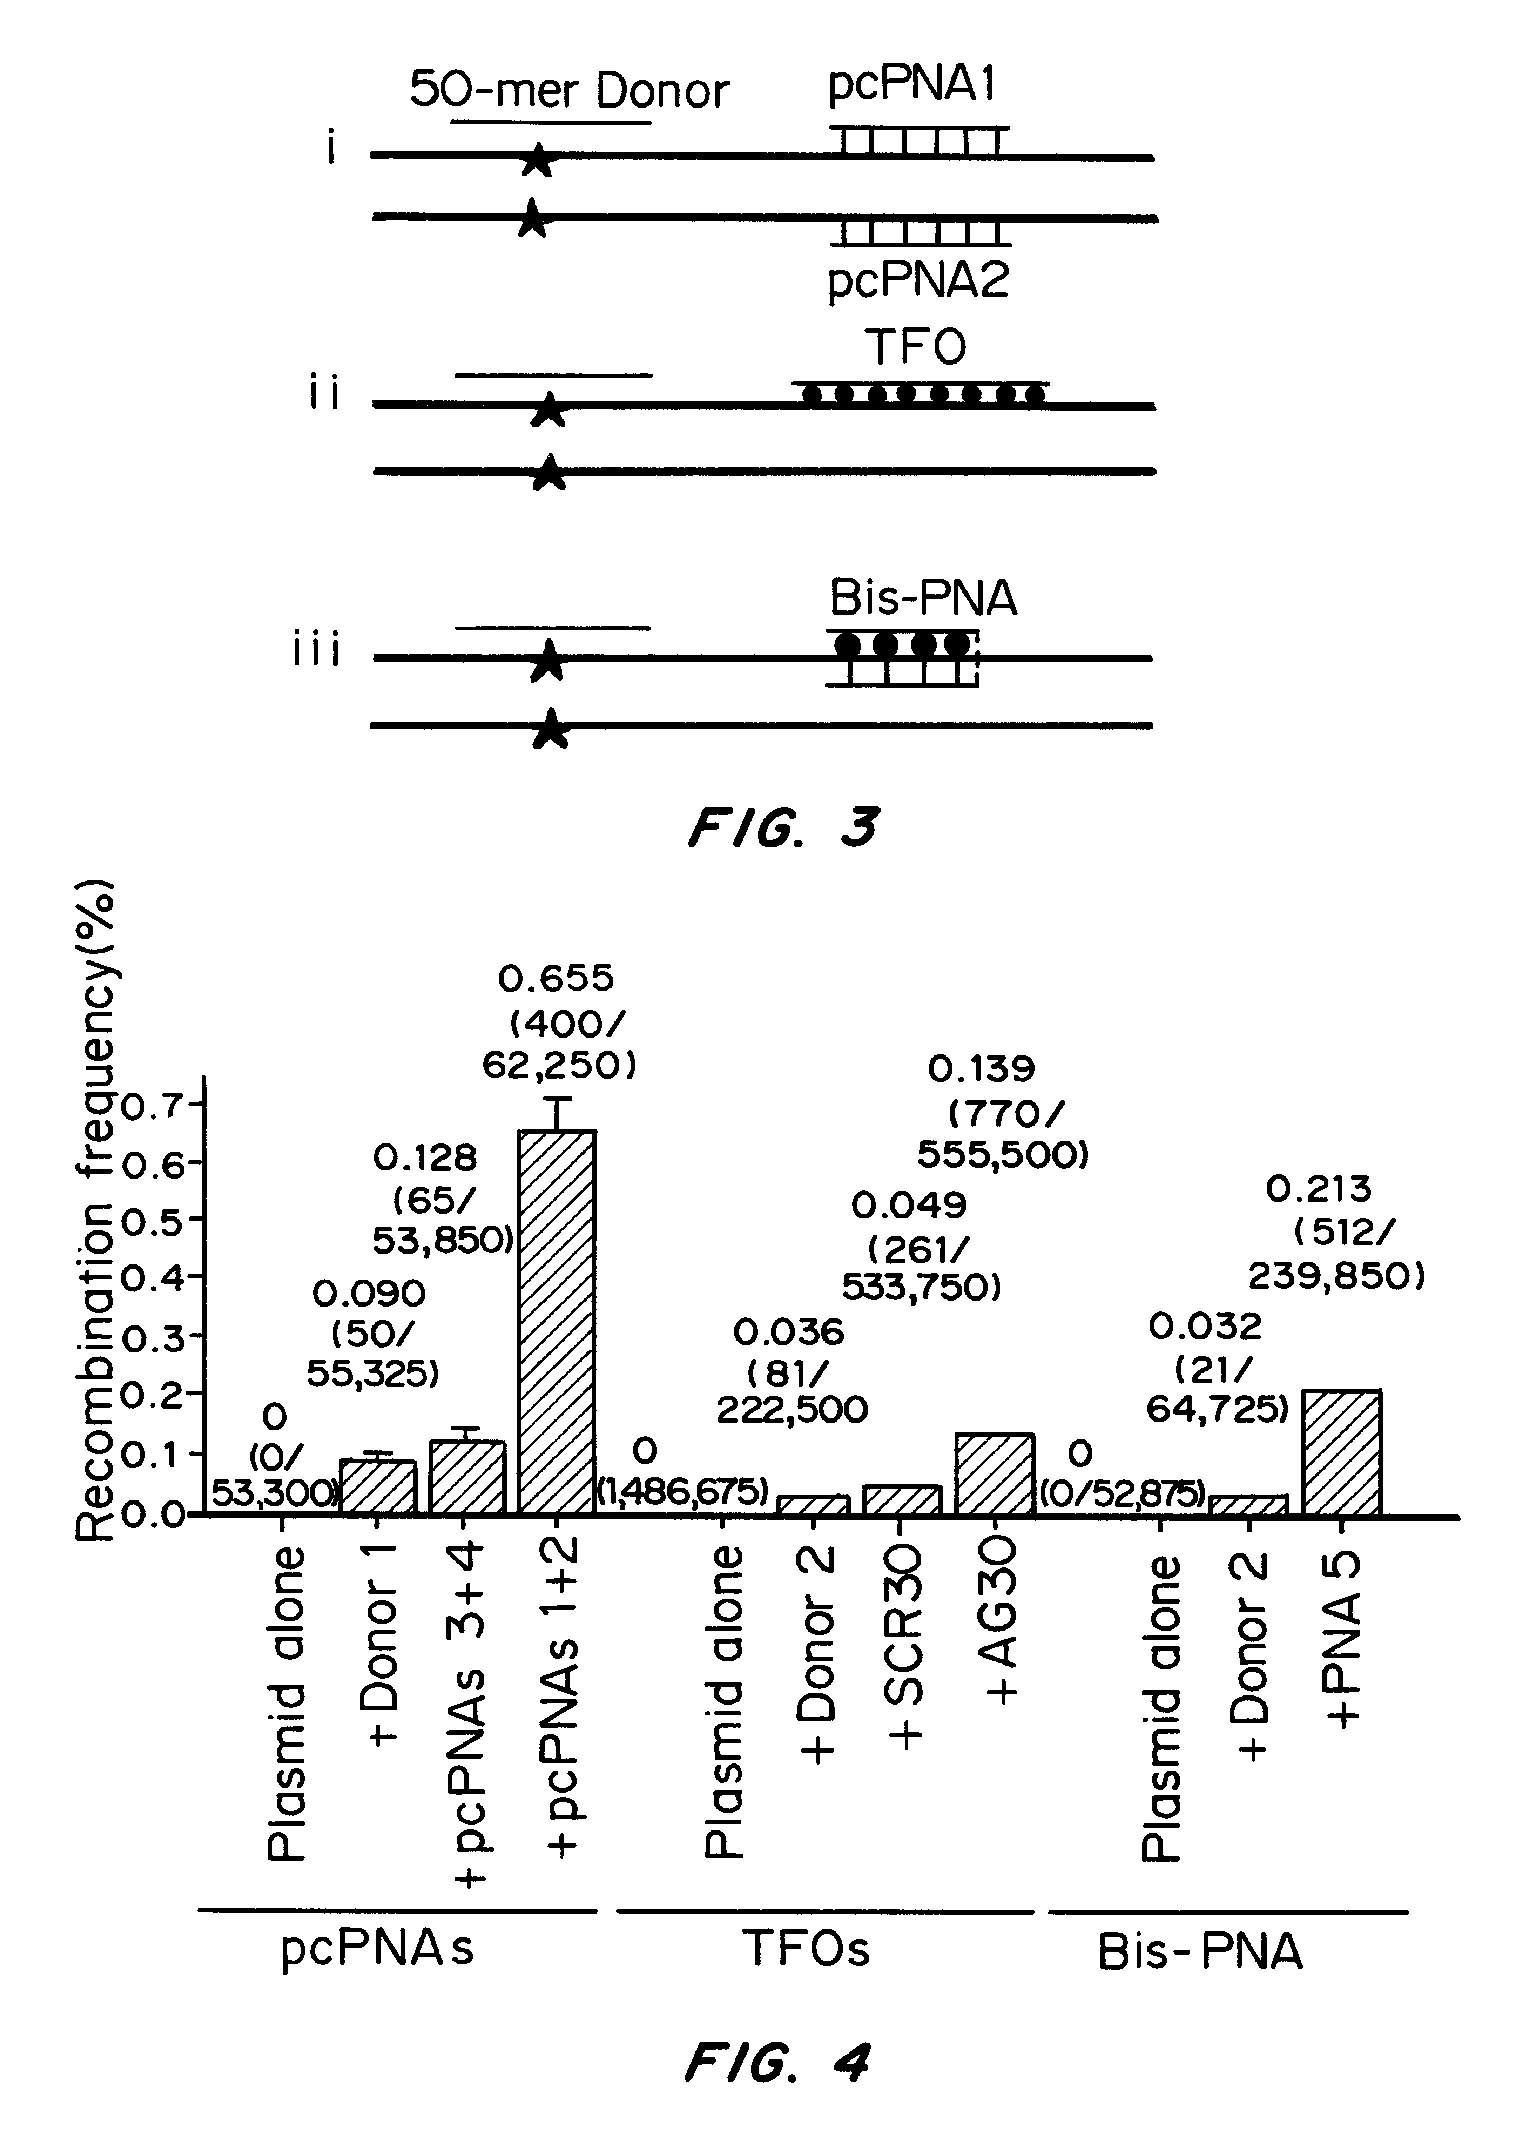
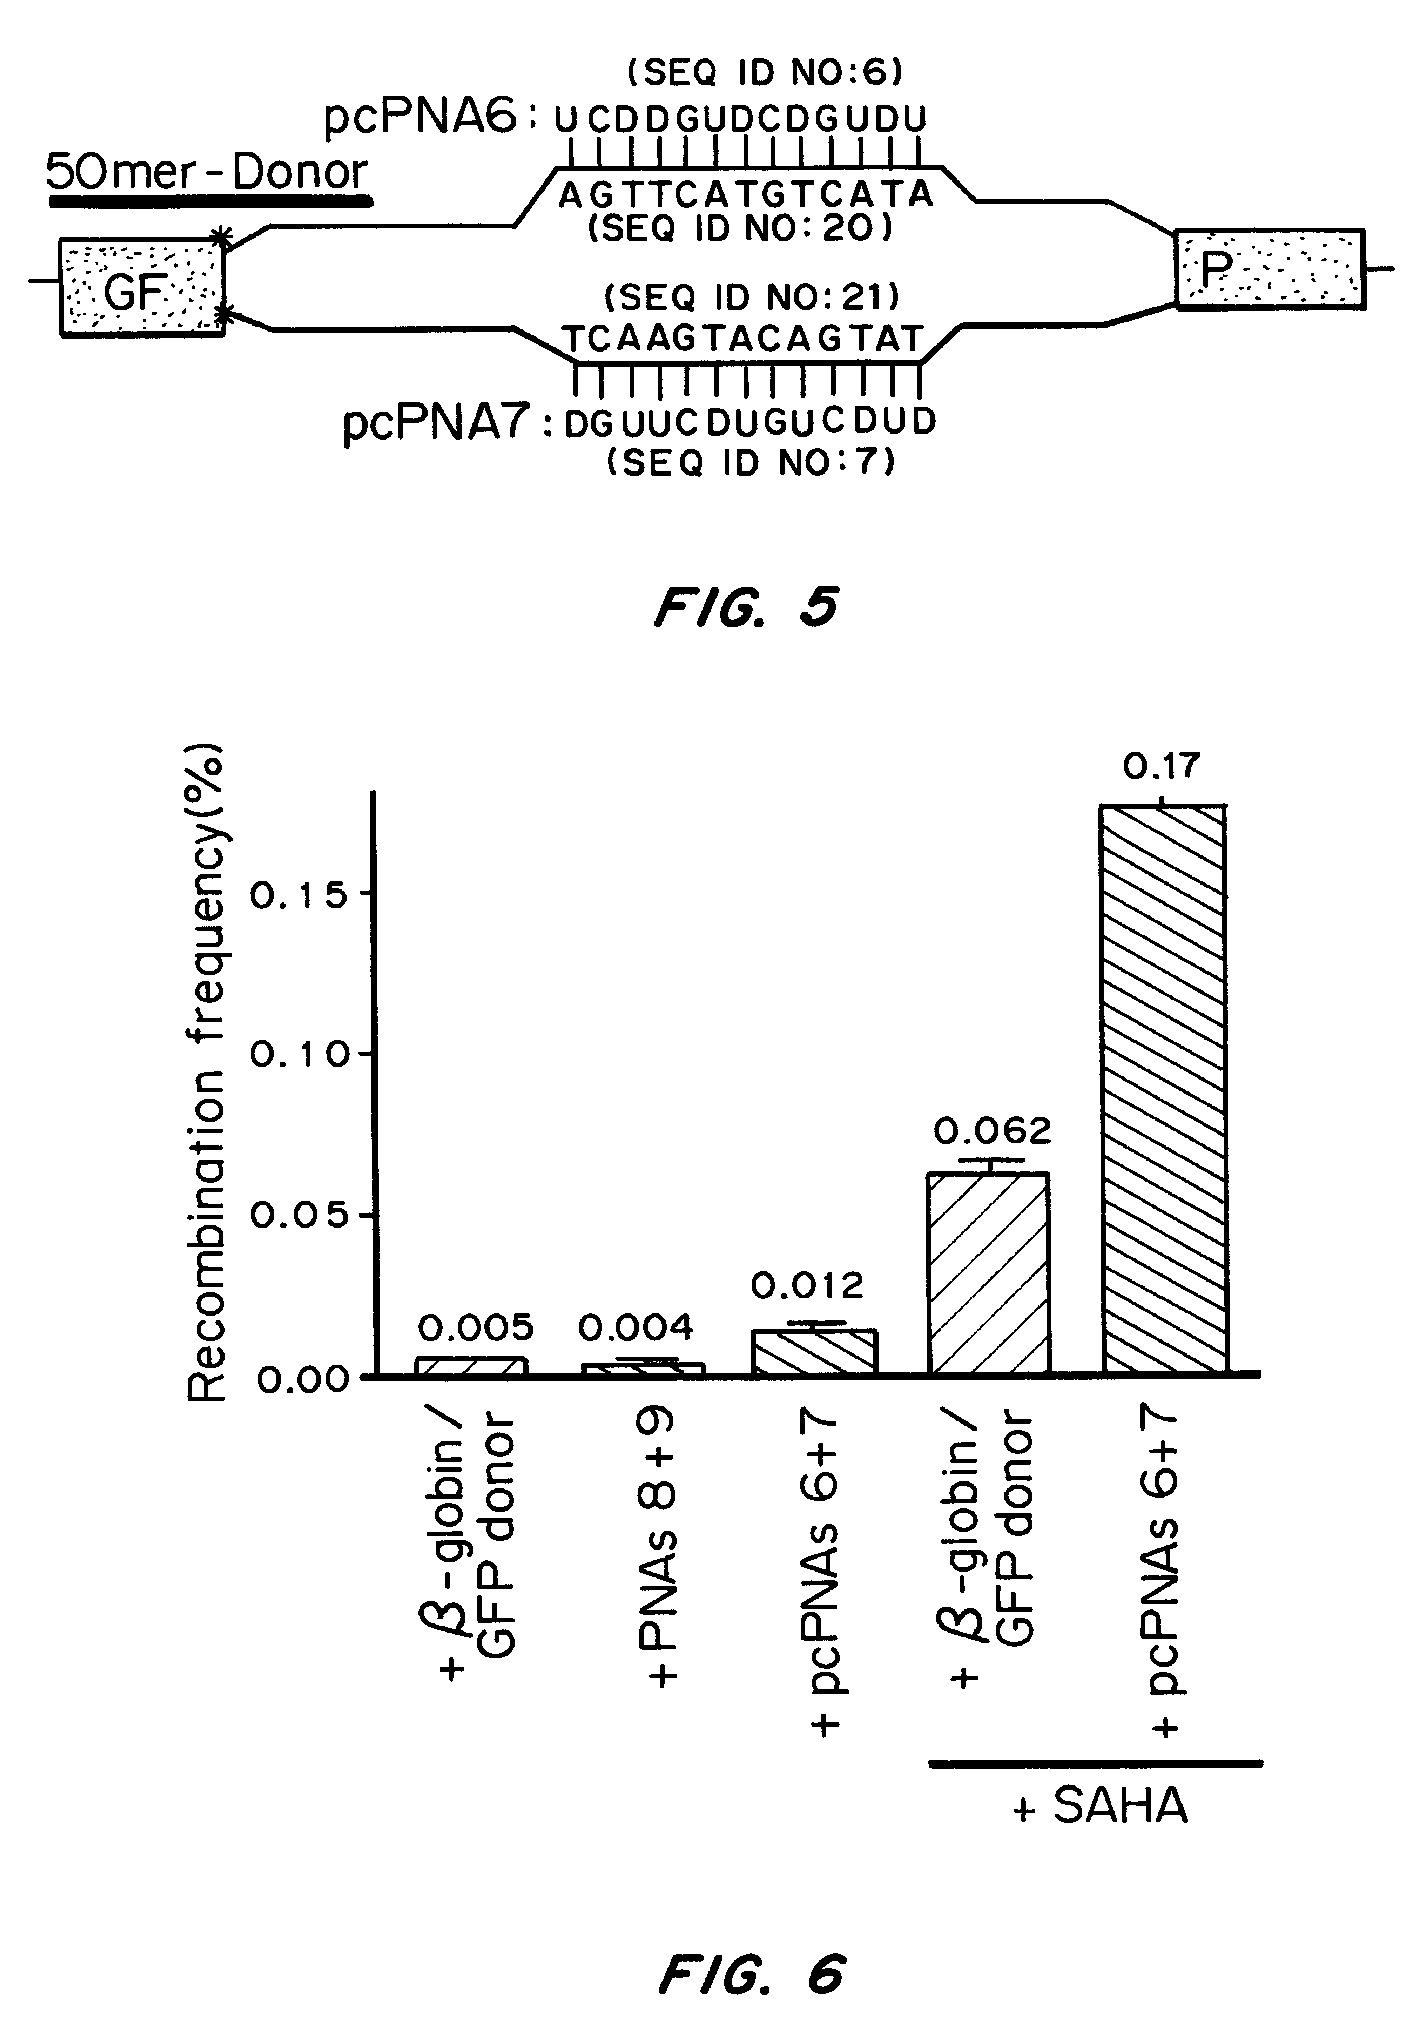
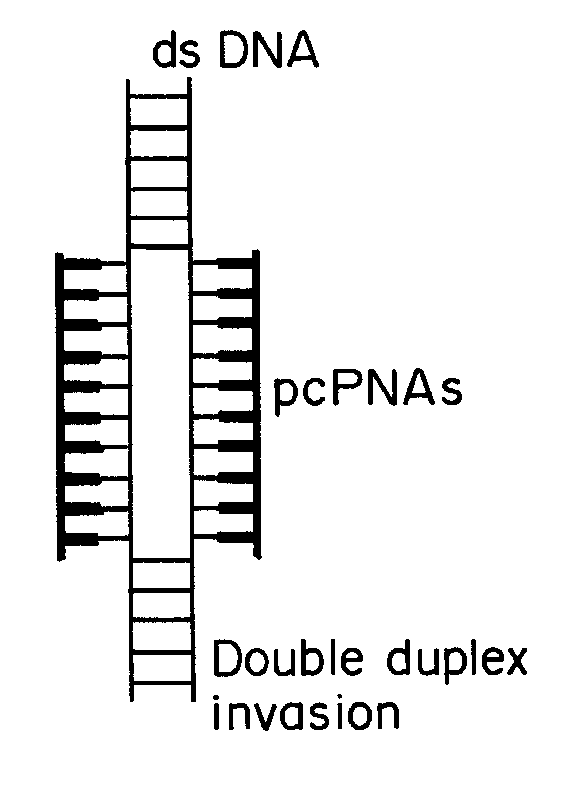
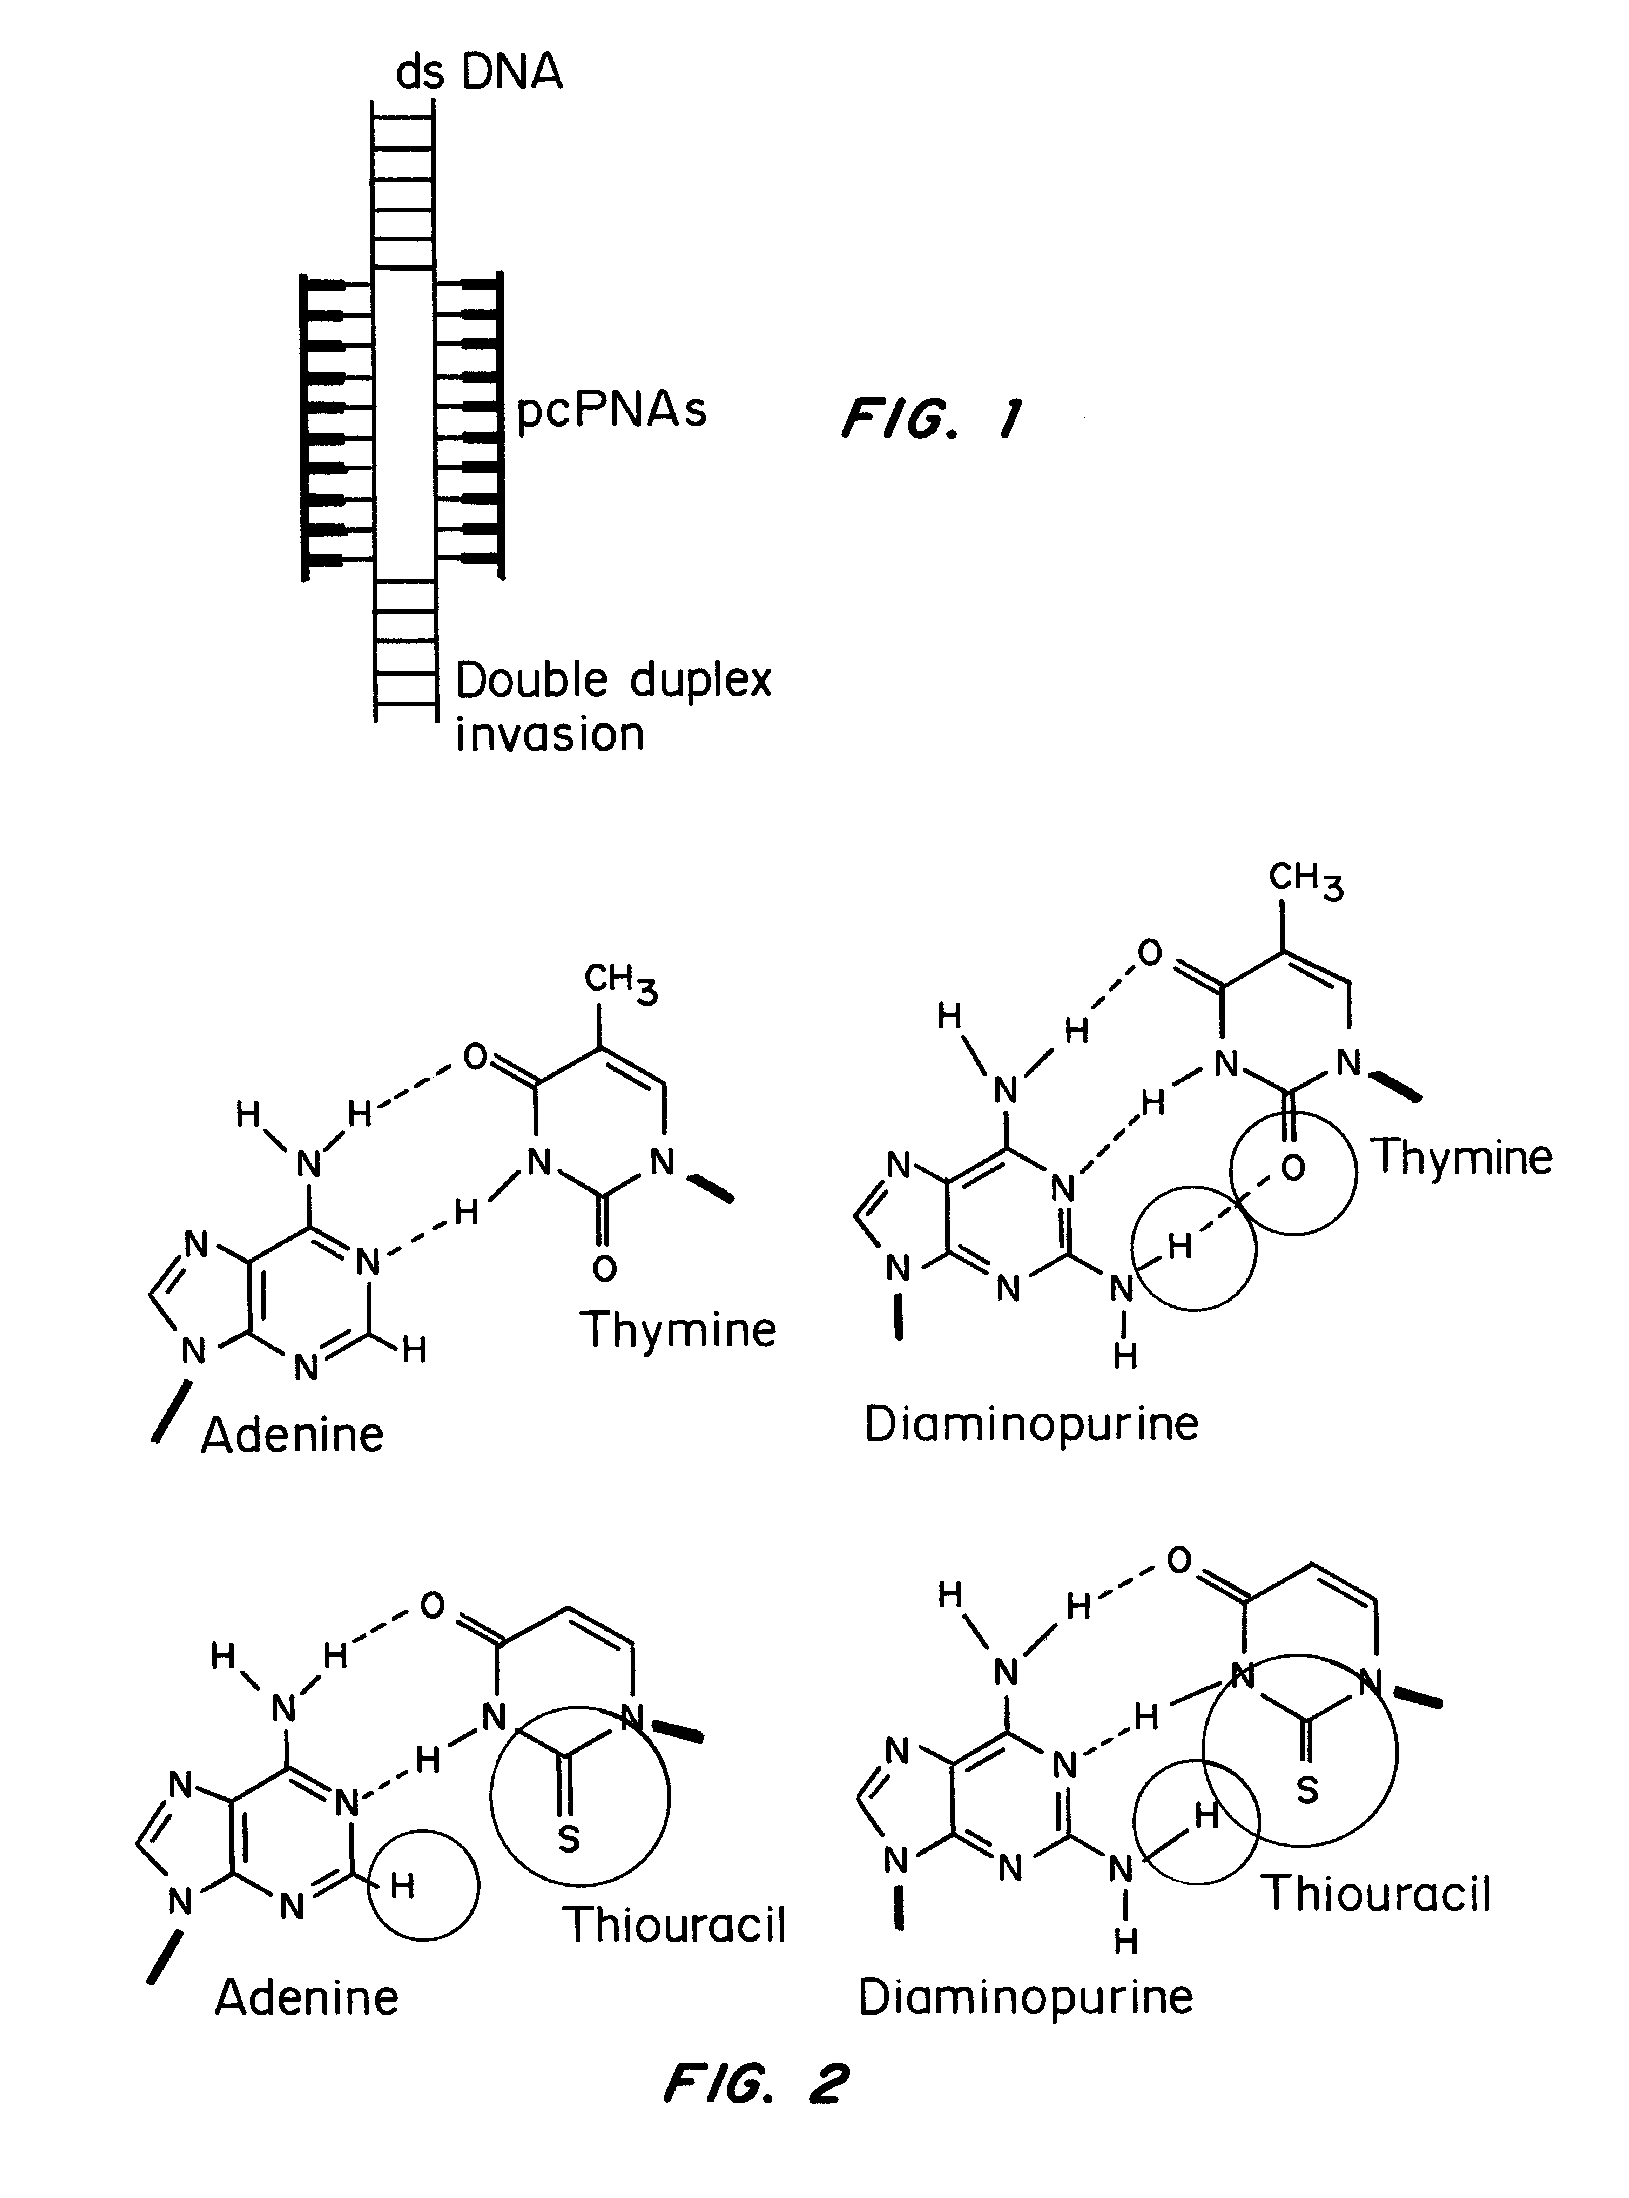
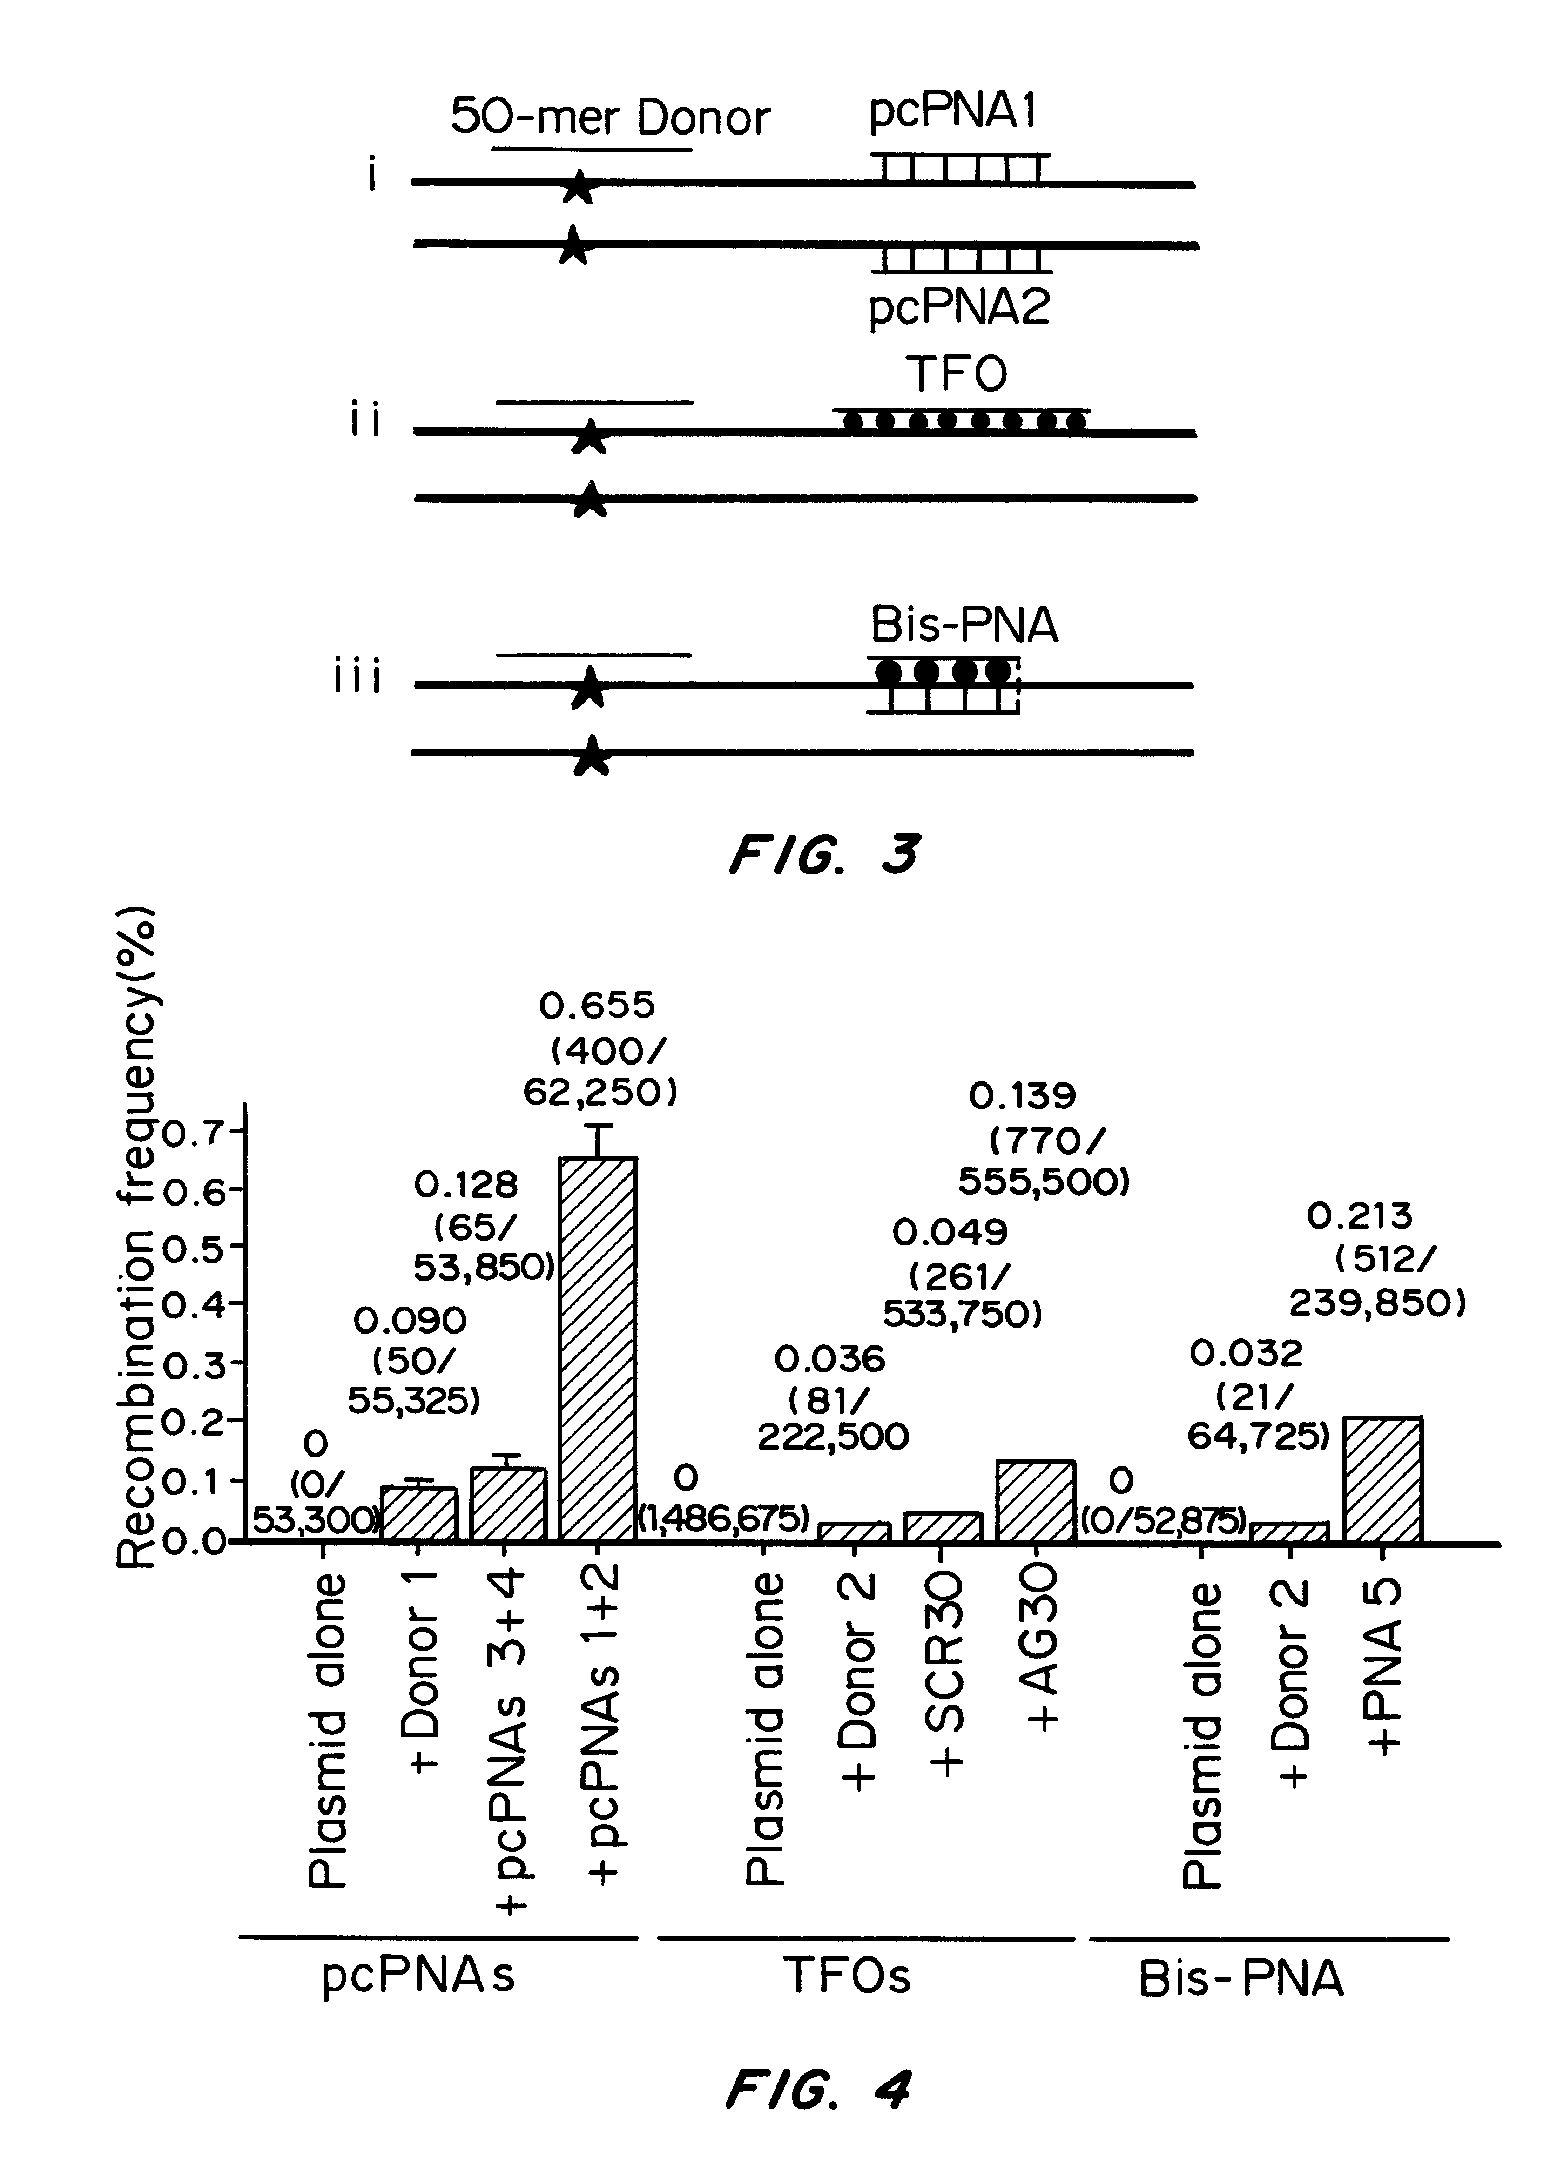
Compositions and methods for targeted gene therapy are disclosed. Compositions containing double duplex-forming pseudocomplementary oligonucleotides are administered in combination with a donor oligonucleotide that is homologous to a target sequence on a double-stranded DNA molecule in need of repair or replacement. By activating cellular mechanisms involved in DNA synthesis, repair and recombination, the double duplex-forming pseudocomplementary oligonucleotides can introduce one or more mutations at a site of interest by increasing the efficiency of targeted recombination of the donor oligonucleotide. The pseudocomplementary oligonucleotides / donor oligonucleotide compositions may be administered in combination with a second therapeutic agent that enhances access of the pseudocomplementary oligonucleotides and / or the donor oligonucleotide to the target site, an agent that enhances or increases DNA repair or recombination, or an agent that enhances uptake or delivery of the oligonucleotides.
Owner:YALE UNIV
Methods of inhibiting metastasis in cancer
InactiveUS20190241665A1Inhibit transferOrganic active ingredientsImmunoglobulins against cytokines/lymphokines/interferonsP-selectinCellular mechanism
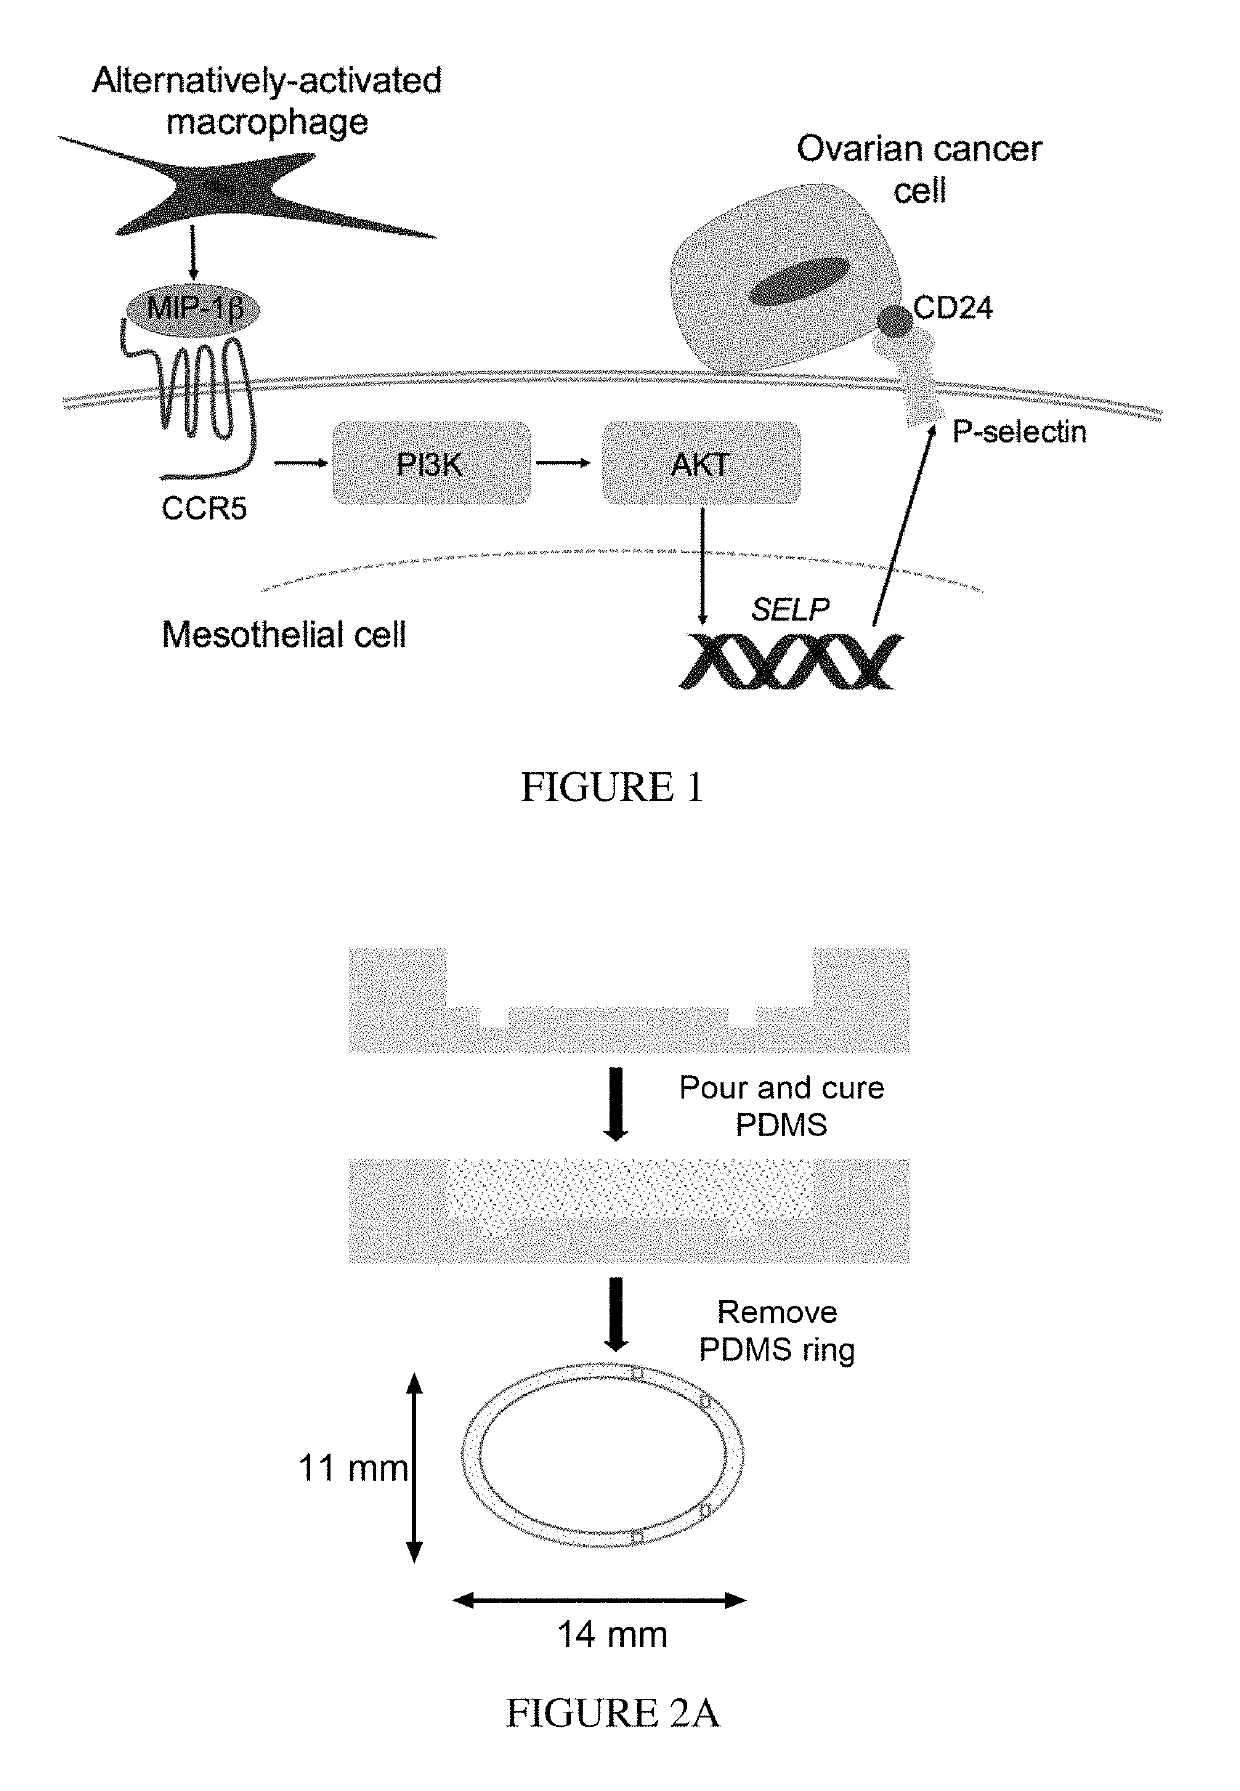
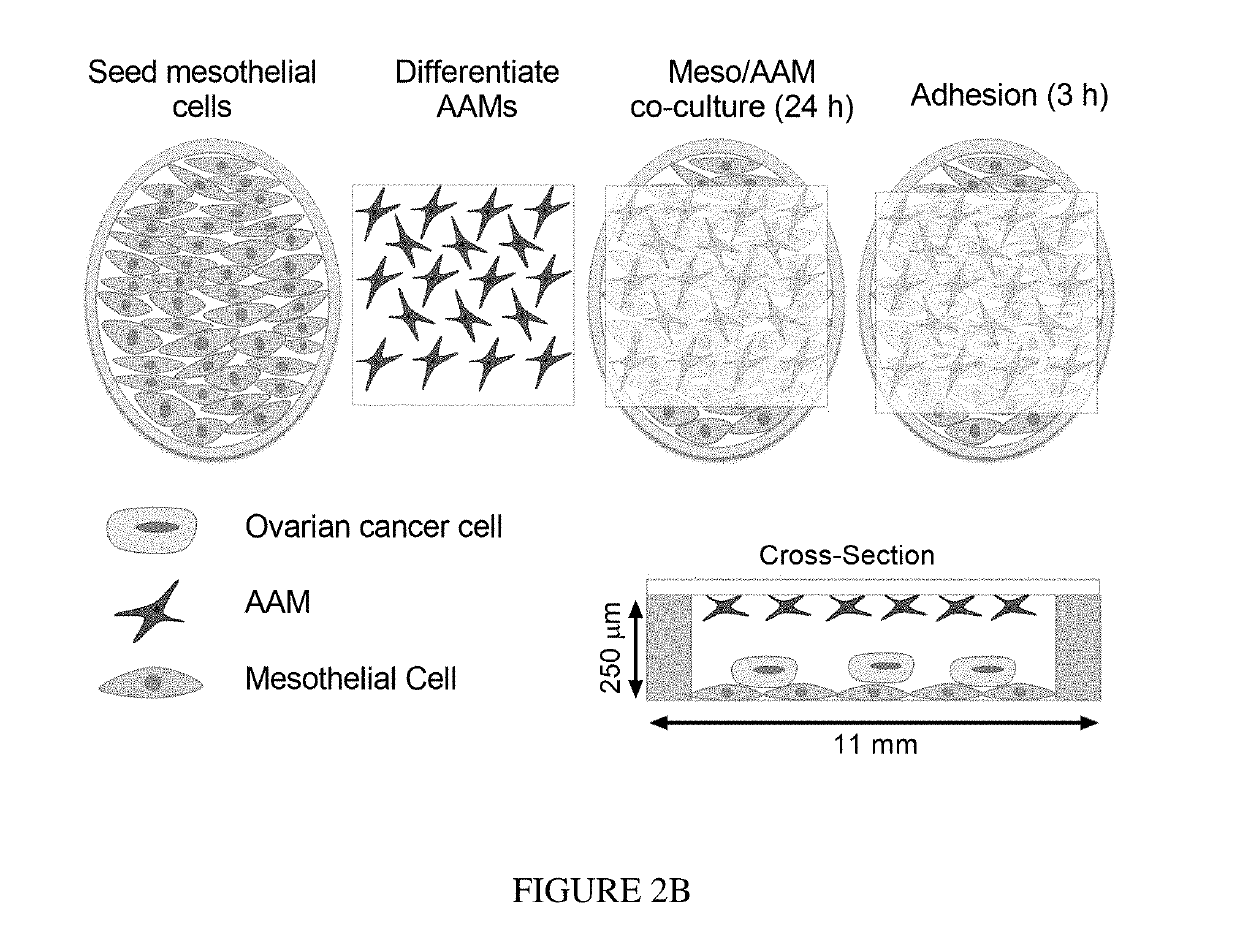
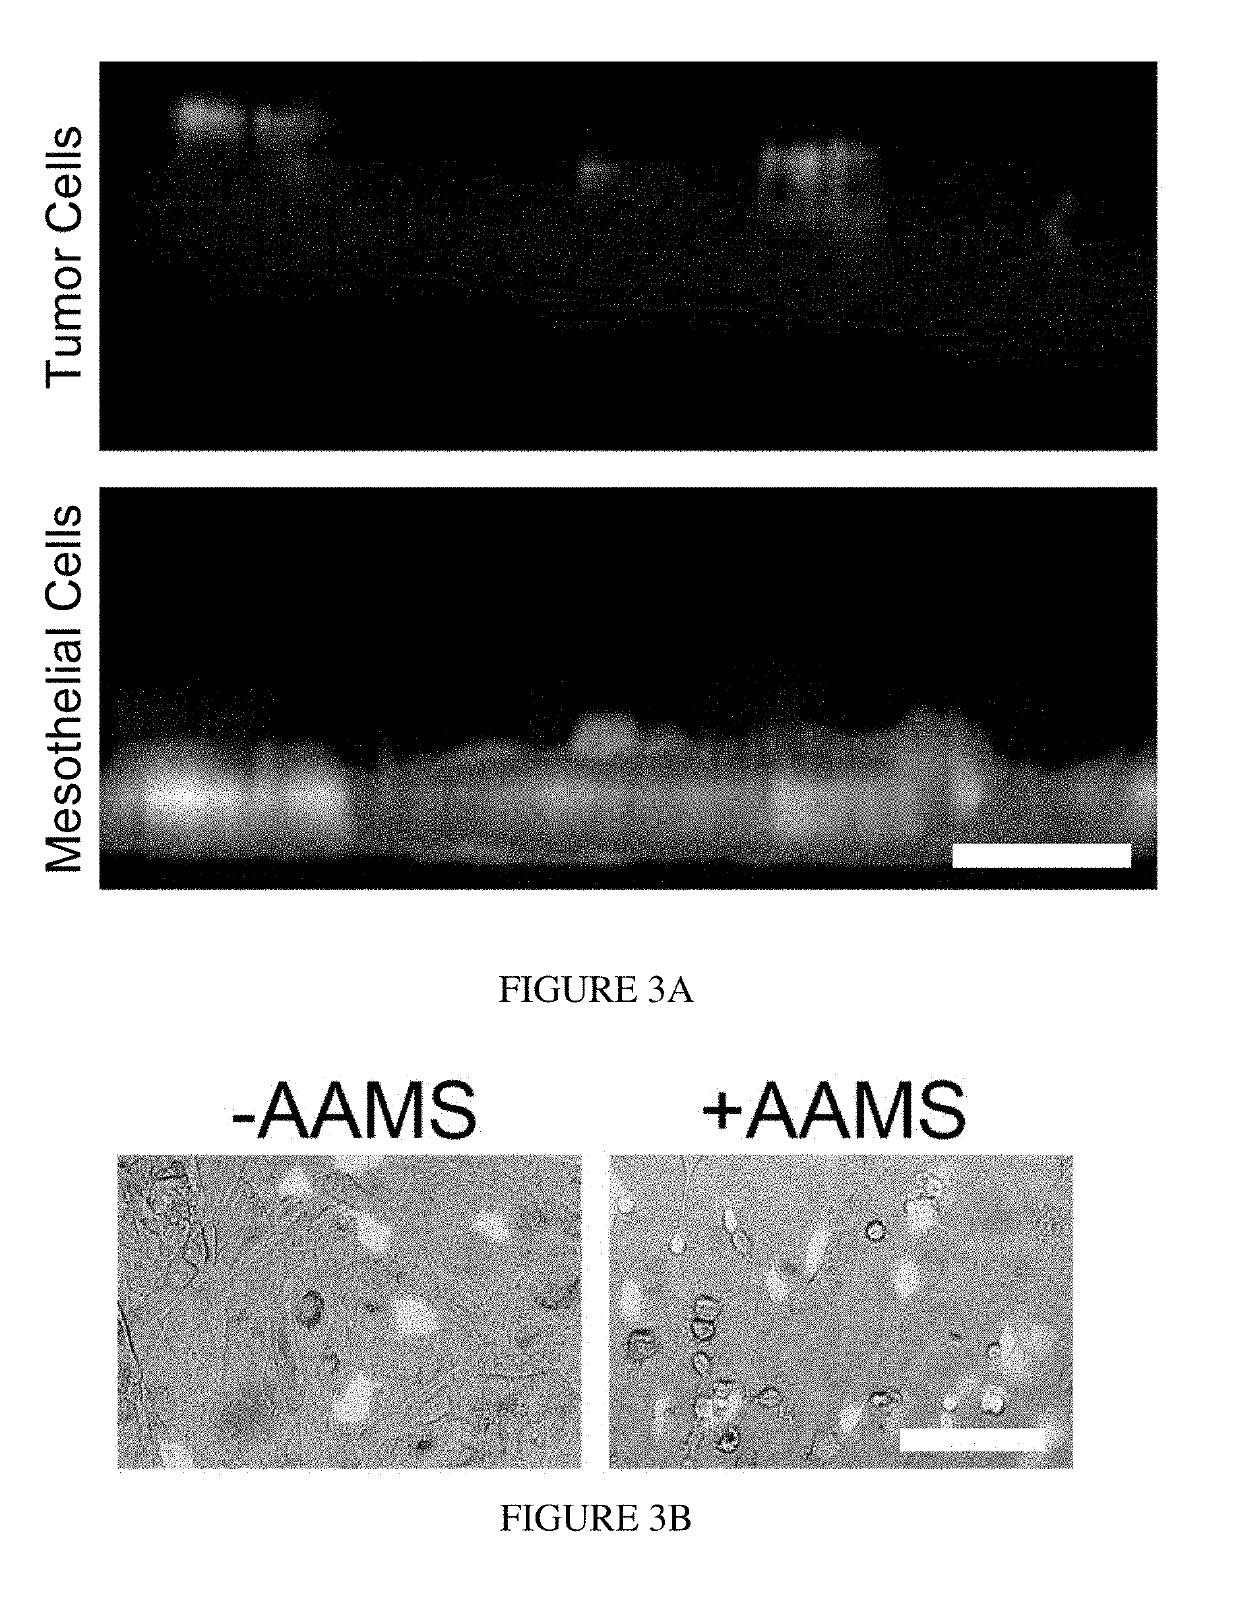
As described herein, a method of inhibiting metastasis in cancer includes administering to a human subject diagnosed with a cancer of an organ of the peritoneal cavity a therapeutically effective amount of an inhibitor of CCR5 or P-selectin. Preferably the subject has a tumor positive for a ligand of P-selectin such as a CD24+ or PSGL-1+ tumor. Analysis of samples from HGSOC patients confirmed increased MIP-1β and P-selectin, suggesting that this novel multi-cellular mechanism can be targeted to slow or stop metastasis in cancers such as high-grade serous ovarian cancer, for example by using anti-CCR5 and P-selectin therapies developed for other indications.
Owner:WISCONSIN ALUMNI RES FOUND
NTDs (neural tube defects) rat embryo animal model and constructing method thereof
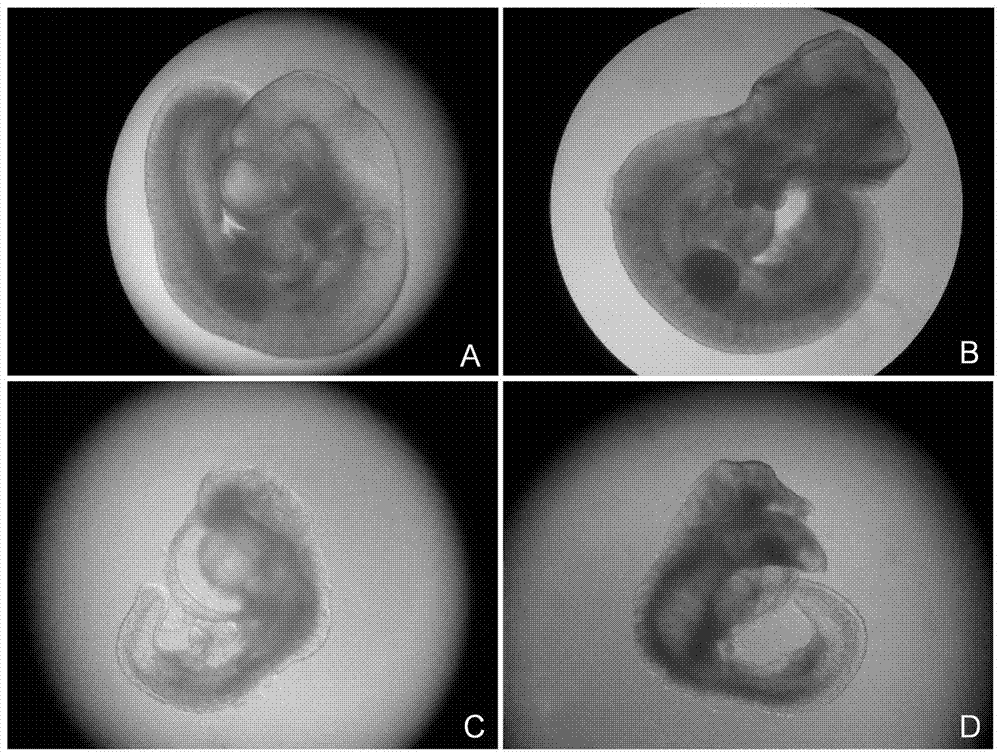
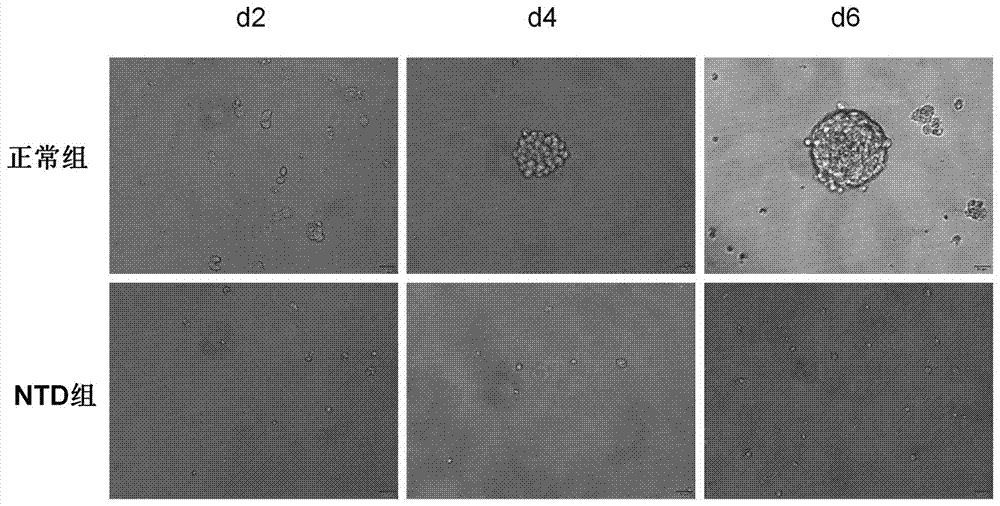
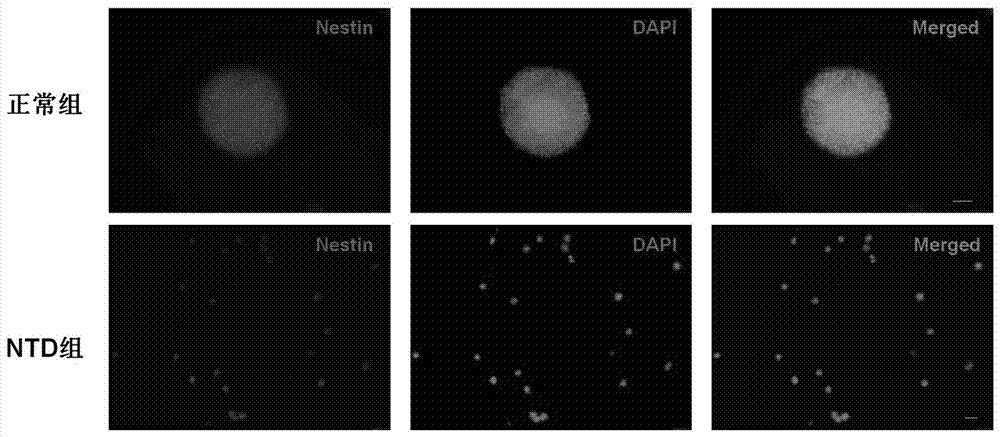
The invention discloses an NTDs (neural tube defects) rat embryo animal model and a constructing method thereof. Normal pregnant rats which have been pregnant for 6 to 10 days are injected with 19-23 mg / kg of retinoic acid at one time for intragastric administration intervention, then construction of the stable and efficient NTDs rat embryo animal mode can be induced rapidly after pregnant 10.5 days, and further, rat embryo brain vesicle tissue is separated out for cell culture while an NTDs cell model can be built. The animal model and the cell model constructed by the method can provide good platforms for research on NTDs molecular mechanism and cellular mechanism in vivo and vitro.
Owner:SHANXI MEDICAL UNIV
Three-dimensional culture containing human articular chondrocytes with induced terminal differentiation changes and preparation process and uses of the same
ActiveUS8470522B2Microbiological testing/measurementArtificial cell constructsDiseaseBiological property
Disclosed herein is a three-dimensional culture containing human articular chondrocytes with induced terminal differentiation changes, as well as a process for preparing the same. The three-dimensional culture, which was found to mimic the biological characteristics of articular chondrocytes that undergo terminal differentiation in vivo, can be used as a tool in the studies of the molecular and cellular mechanisms of osteoarthritis, and in the screening of candidate drugs for use in treatment of a disorder associated with articular chondrocytes.


Owner:KAOHSIUNG MEDICAL UNIVERSITY
JAK/STAT pathway inhibitors and uses thereof
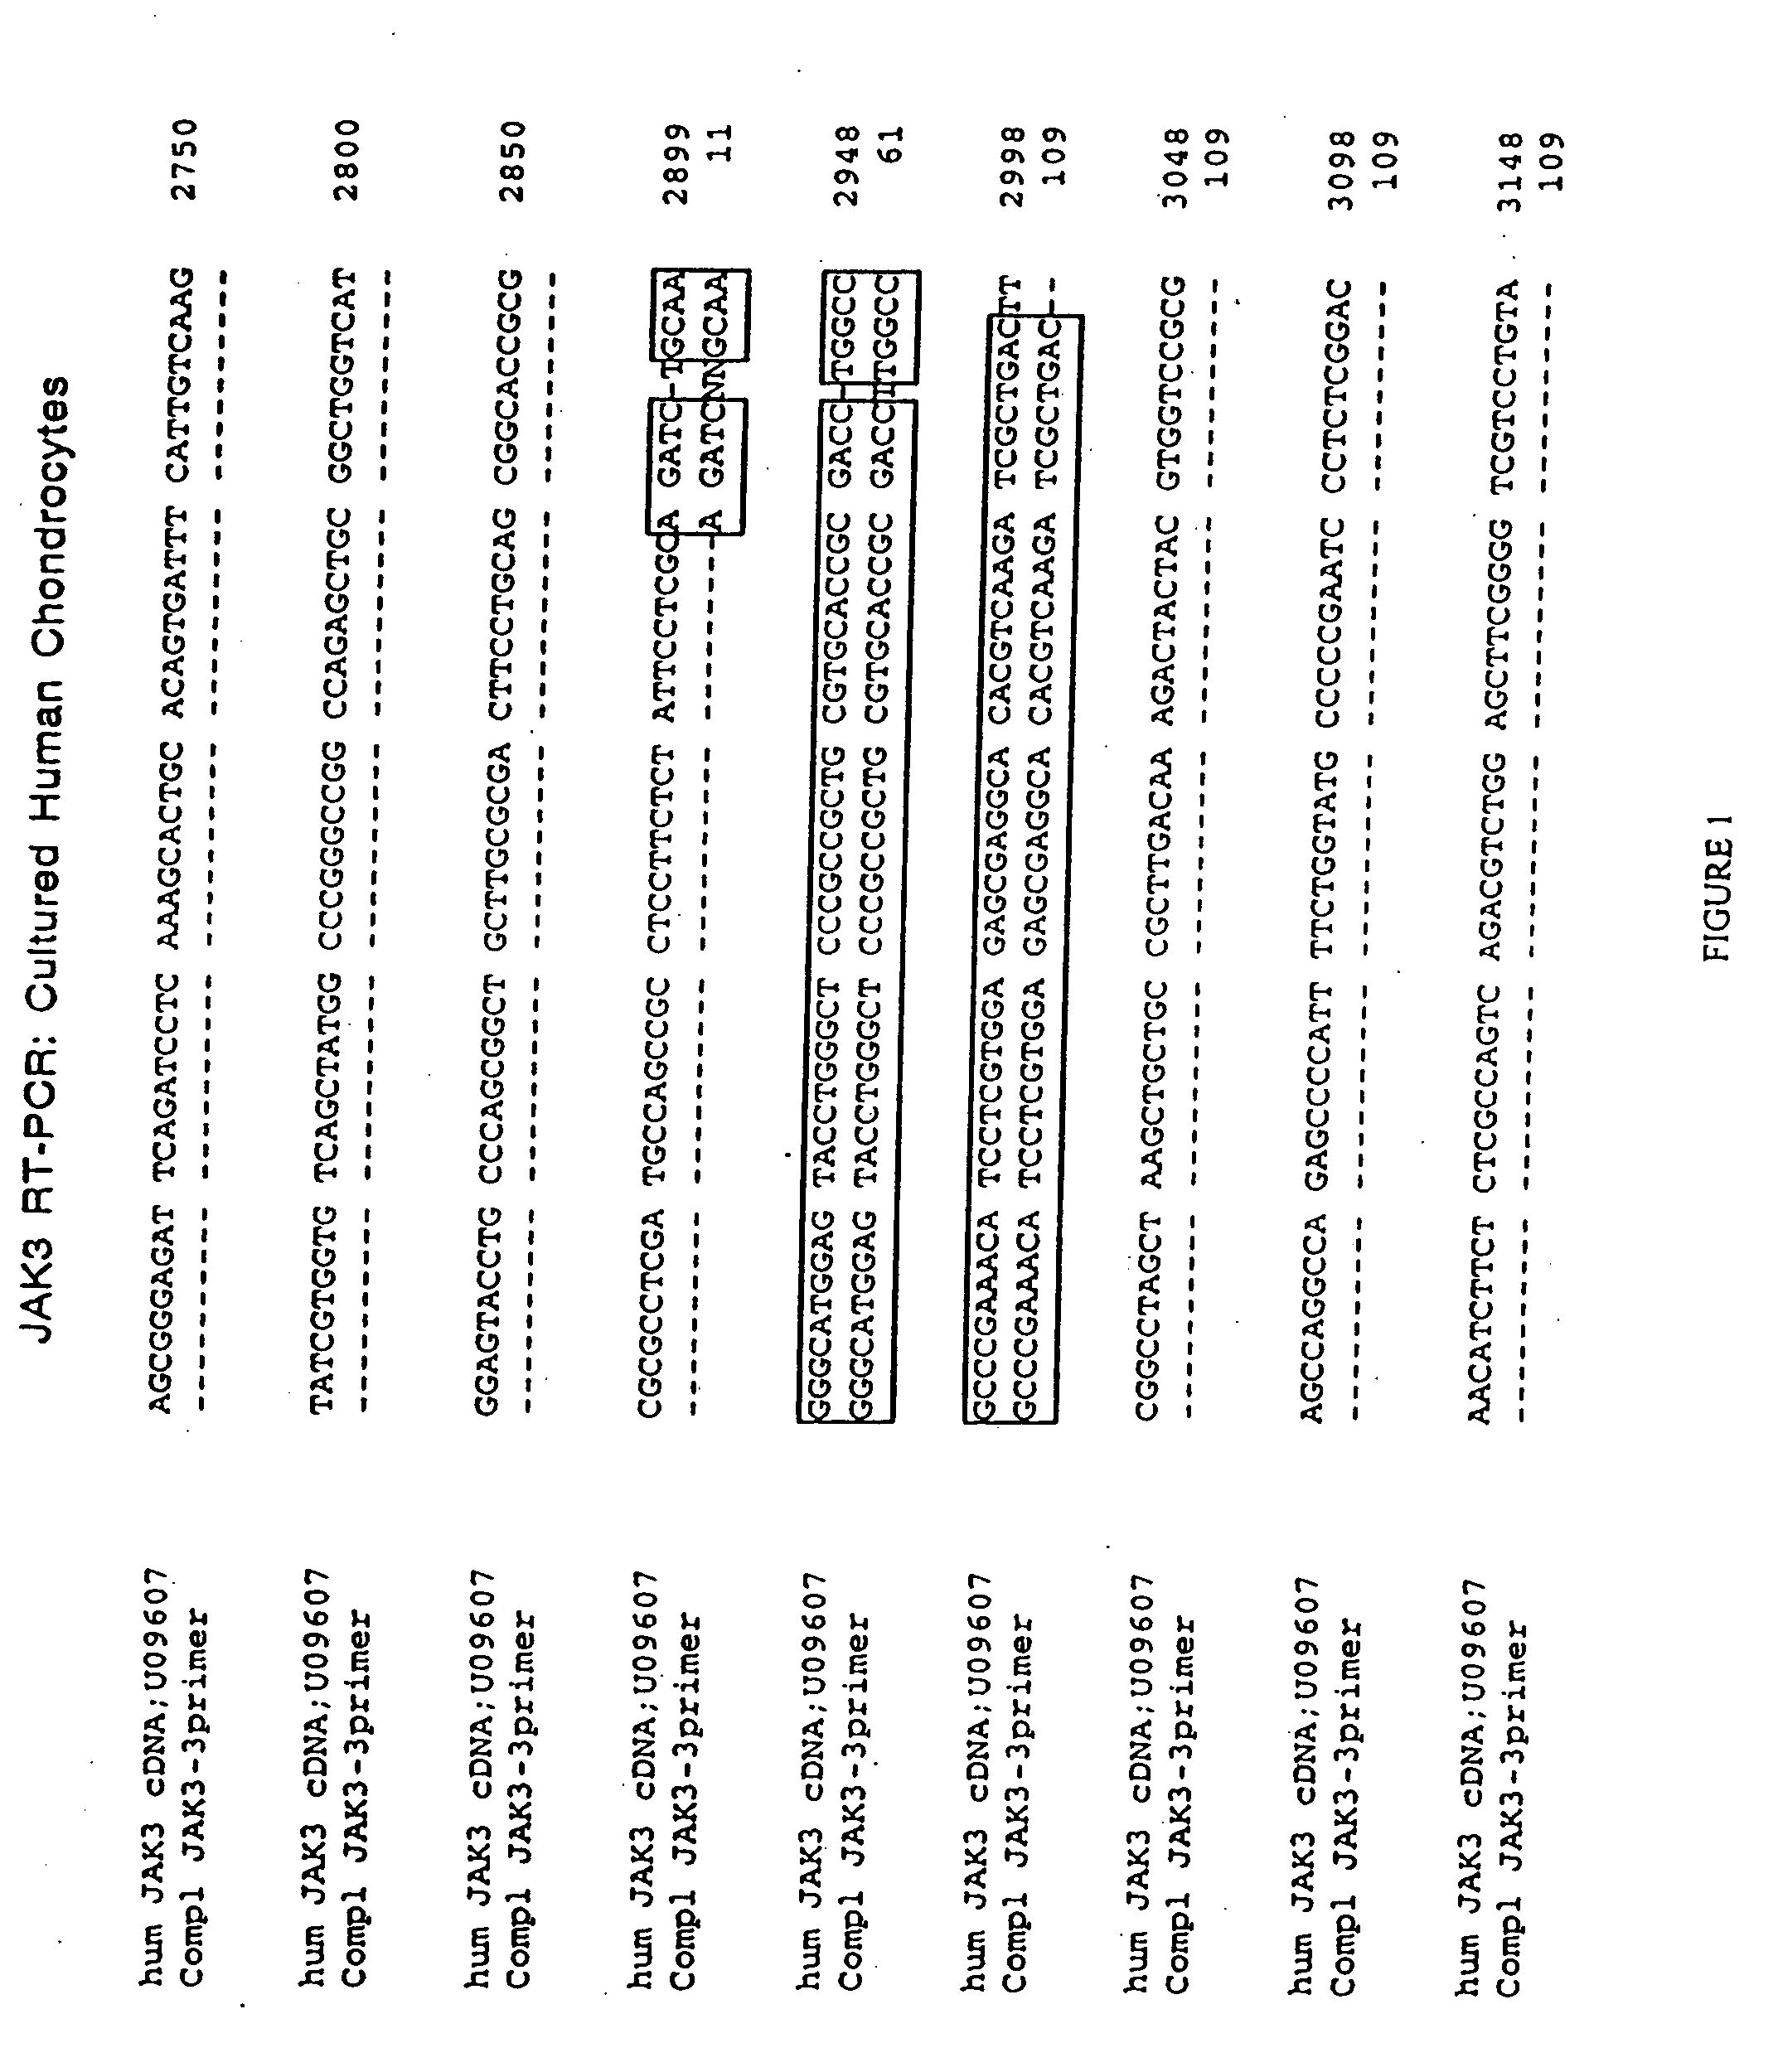
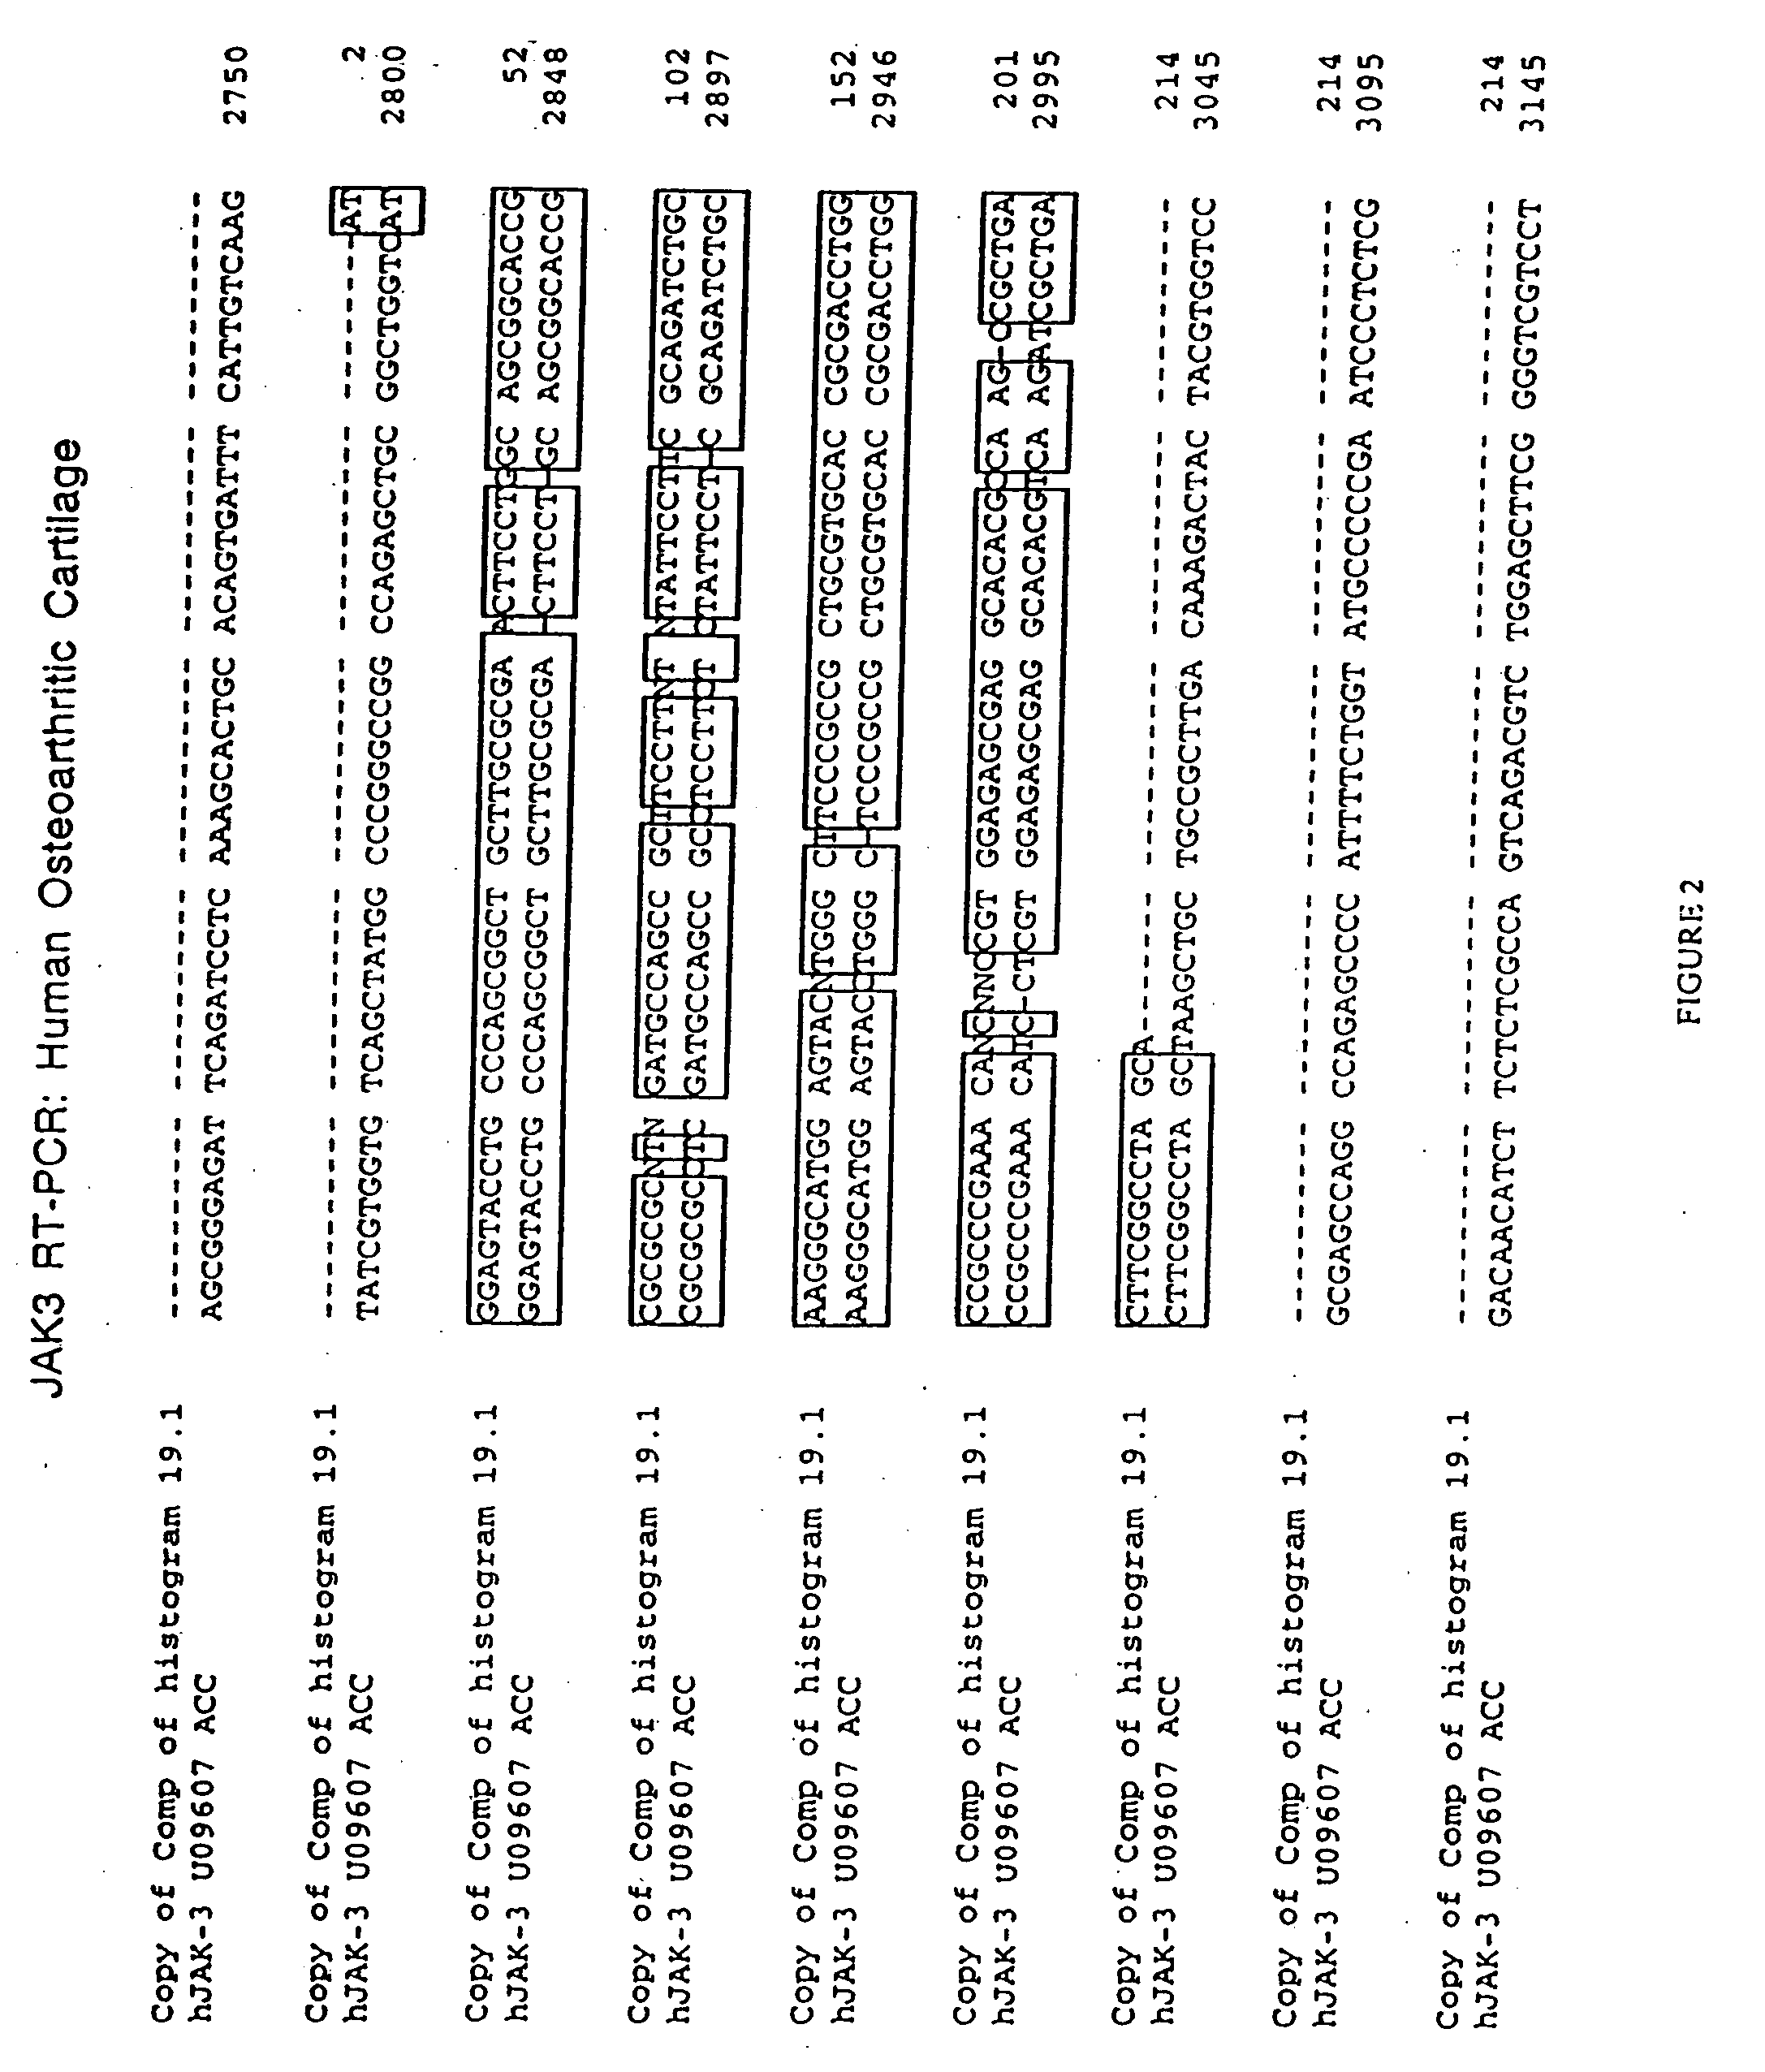
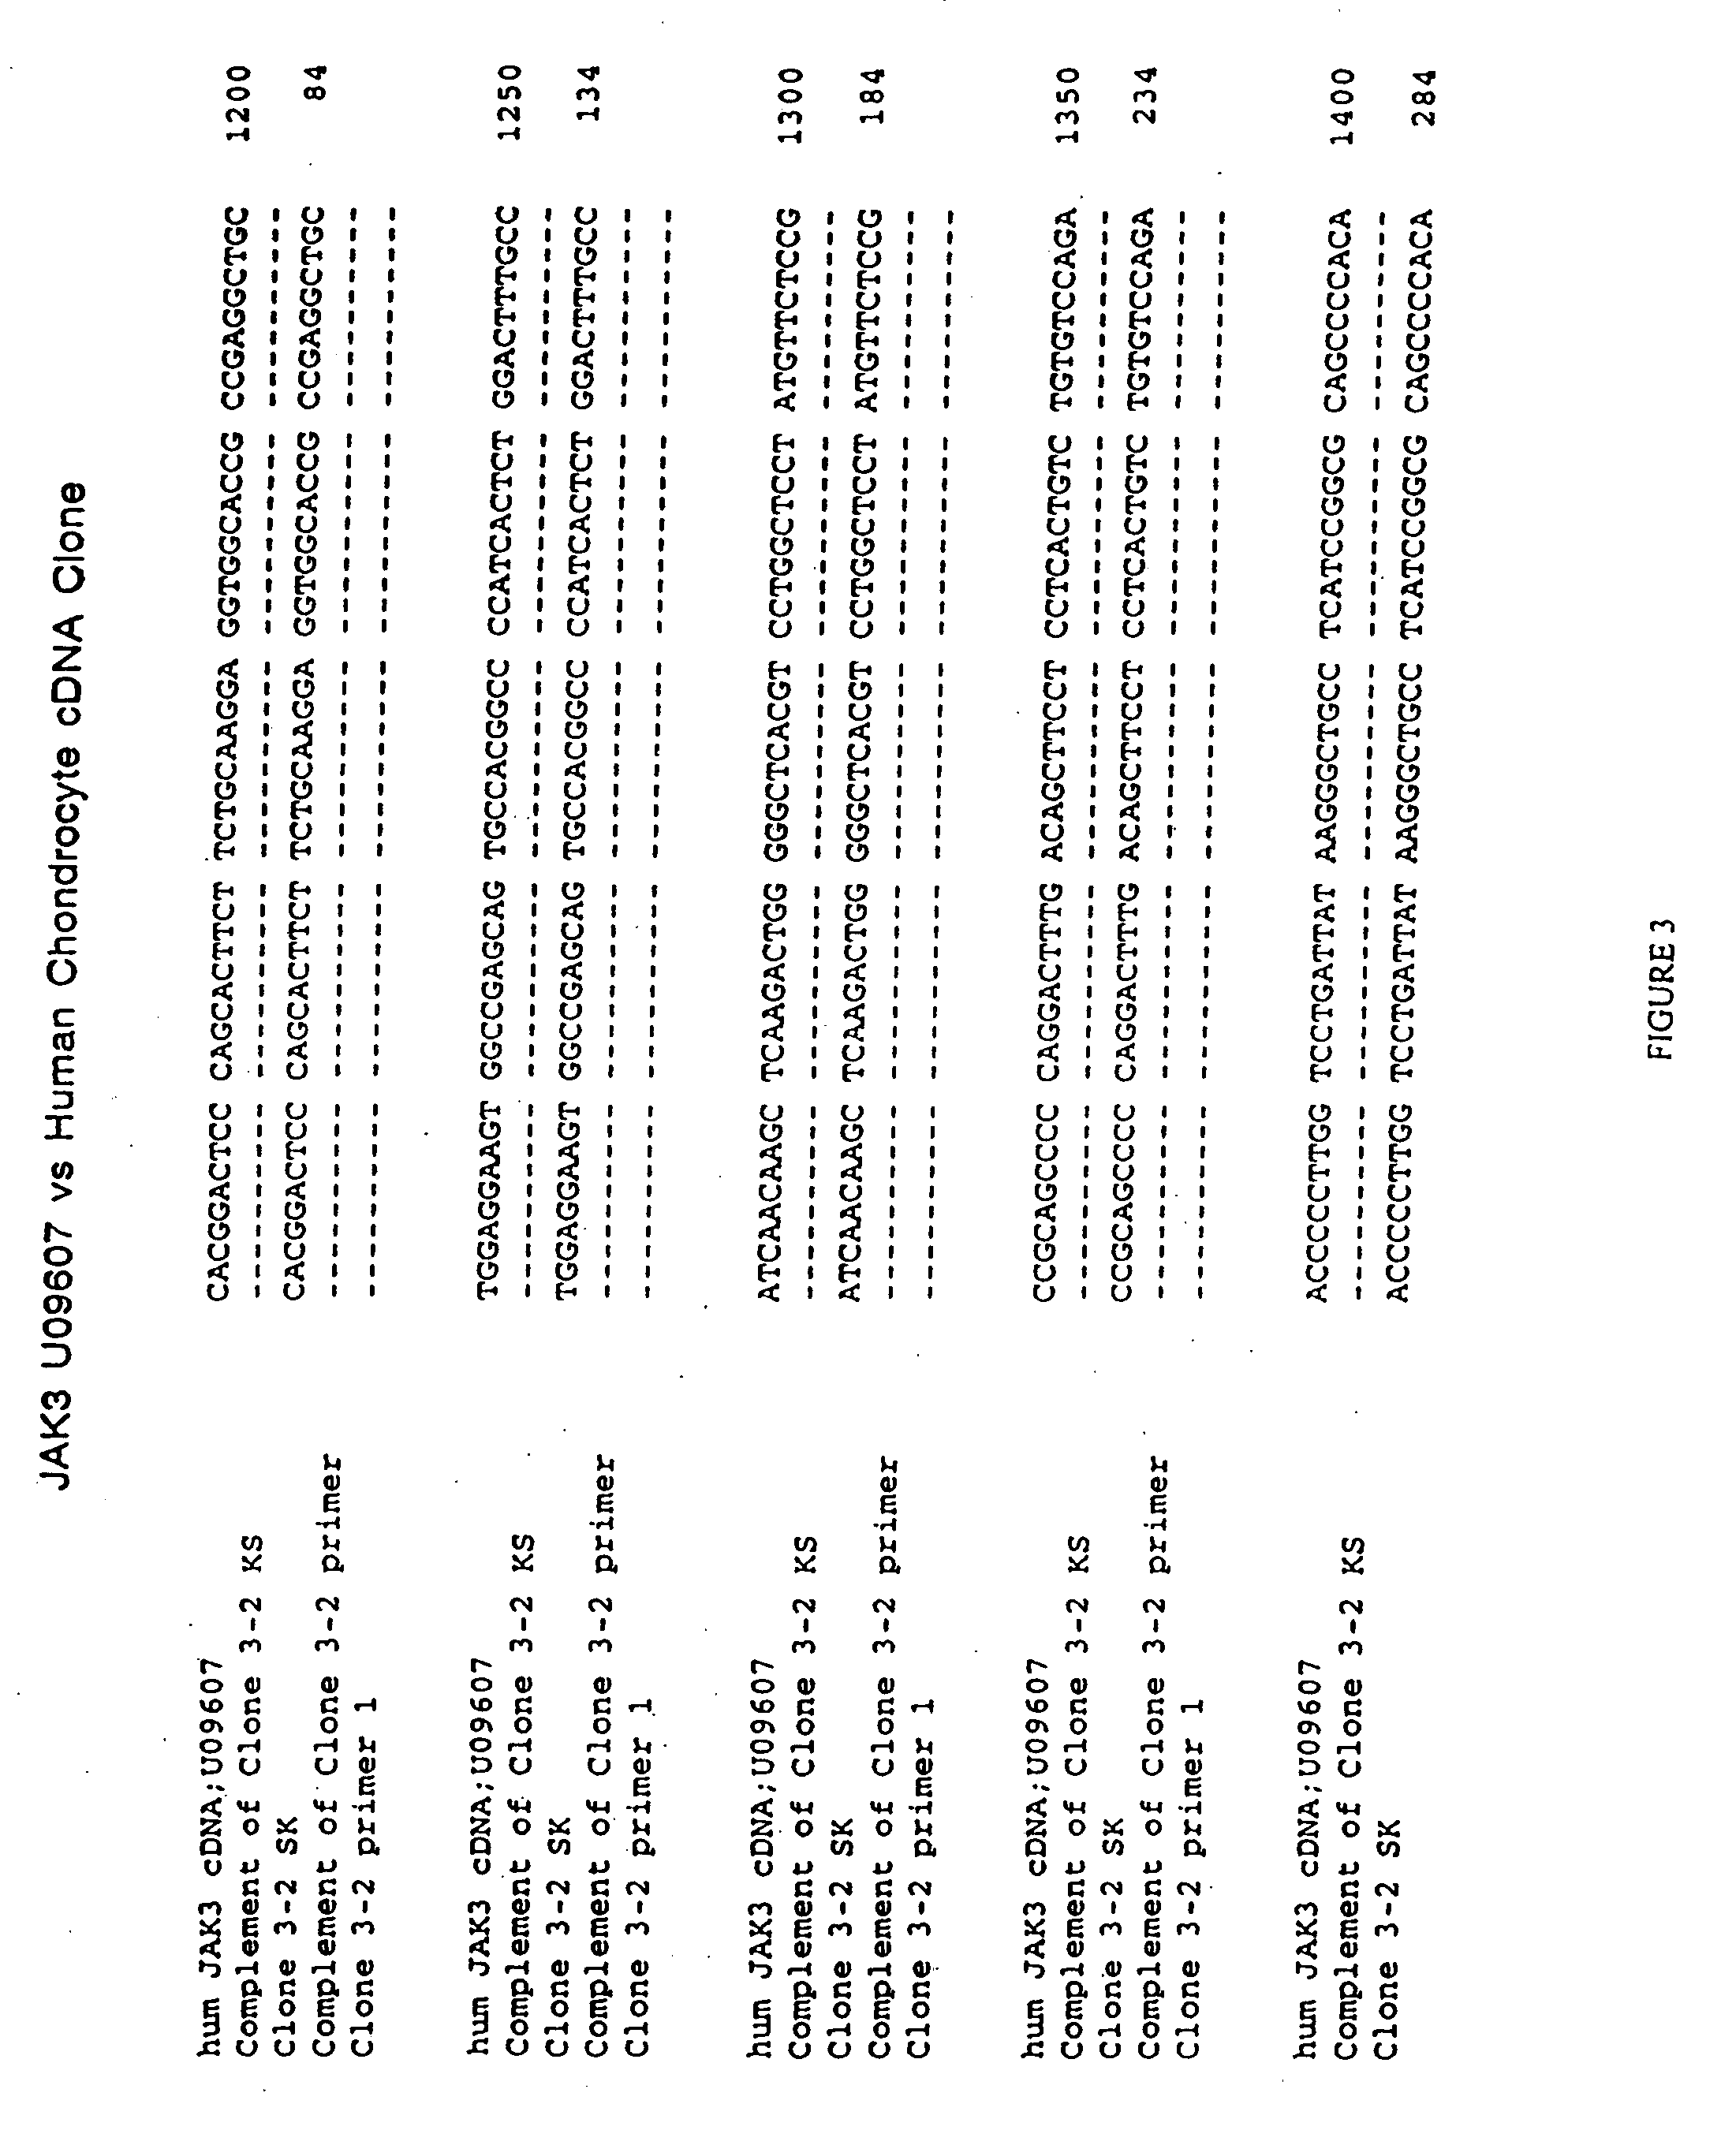
The role of the JAK / STAT signal transduction pathway cellular mechanisms that lead to the onset and progression of degenerative joint diseases or disorders such as osteoarthritis (OA) is disclosed. Certain known effective OA therapeutics such as hymenialdisine, debromohymenialdisine, and its variants and derivatives are shown to function as JAK3-specific inhibitors, which downregulate steady state mRNA levels of key cellular components involved in cartilage degradation. Another JAK3-specific inhibitor, not previously known as an OA therapeutic, is shown to downregulate steady state mRNA levels of various cellular components involved in cartilage degradation in a manner identical to that of the known OA therapeutics.
Owner:GENZYME CORP
Authentication for device with non-cellular access
PendingUS20260067680A1Key distribution for secure communicationSecurity arrangementAccess networkInternet privacy
Example embodiments of the present disclosure relate to authentication for device with non-cellular access. A first apparatus transmits, to a second apparatus, a registration request for a third apparatus. The registration request at least indicates that the third apparatus is accessing a network via a non-cellular mechanism. The first apparatus further receives, from the second apparatus, a first message indicating that the third apparatus is authenticated. Based on the receipt of the first message, the first apparatus further transmits security information to a fourth apparatus for establishing a connection between the third and fourth apparatuses. In this way, the third apparatus can be authenticated. In addition, secure connection can be established between the third and fourth apparatuses.

Owner:NOKIA TECHNOLOGIES OY
Compositions & methods for monitoring DNA repair
PendingUS20210246505A1Convenient researchEasy to implementMicrobiological testing/measurementCellular mechanismDouble Strand Break Repair
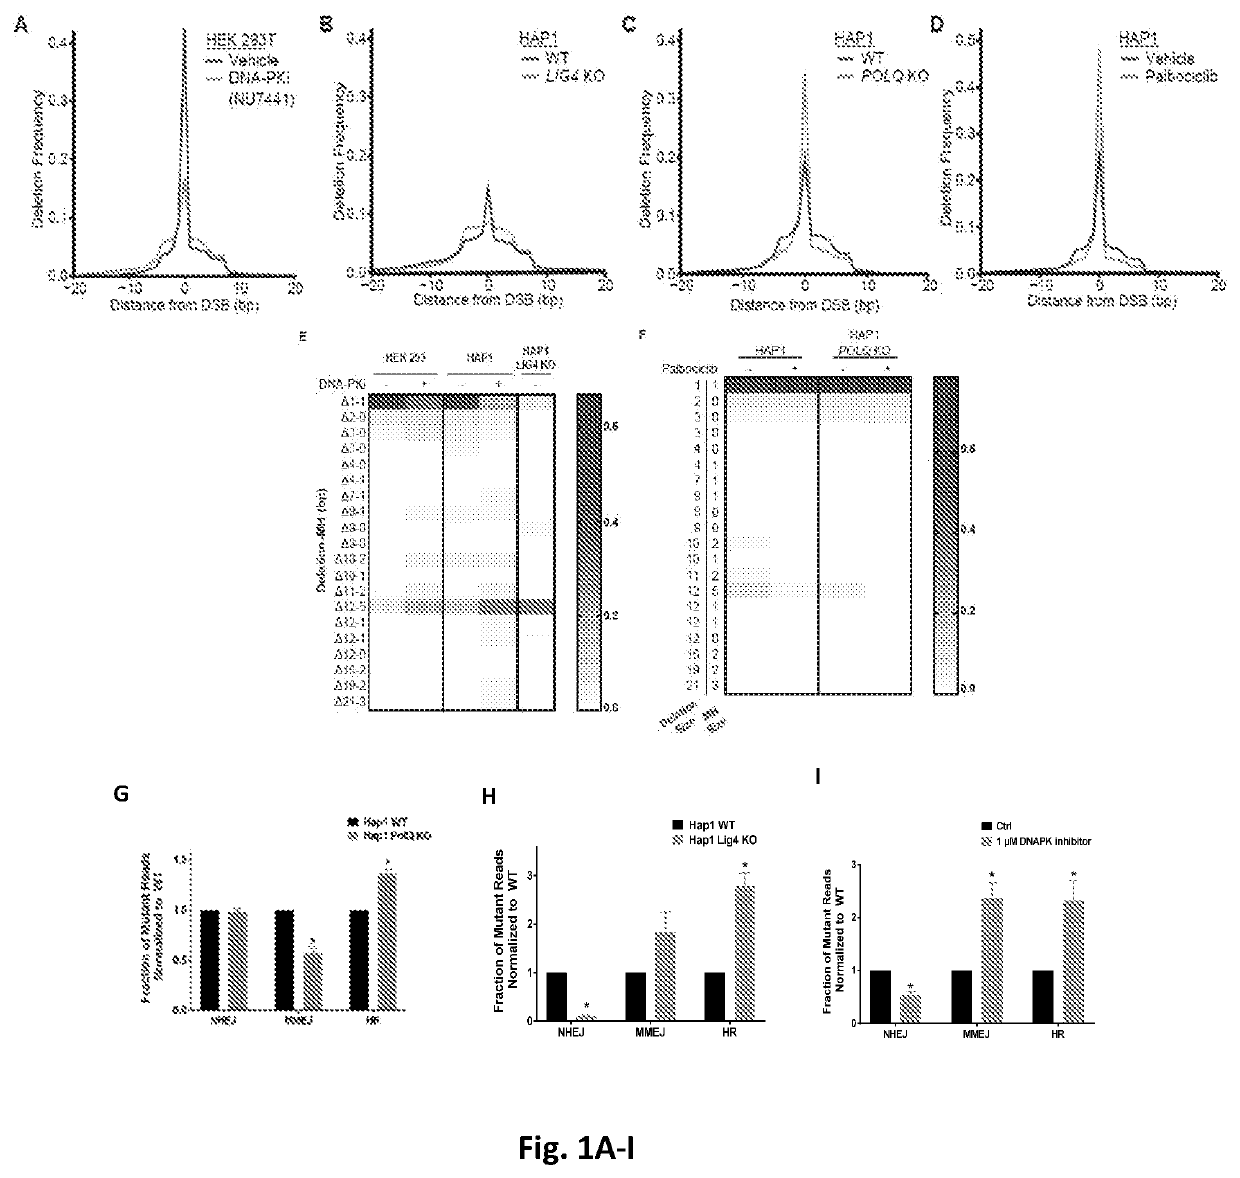
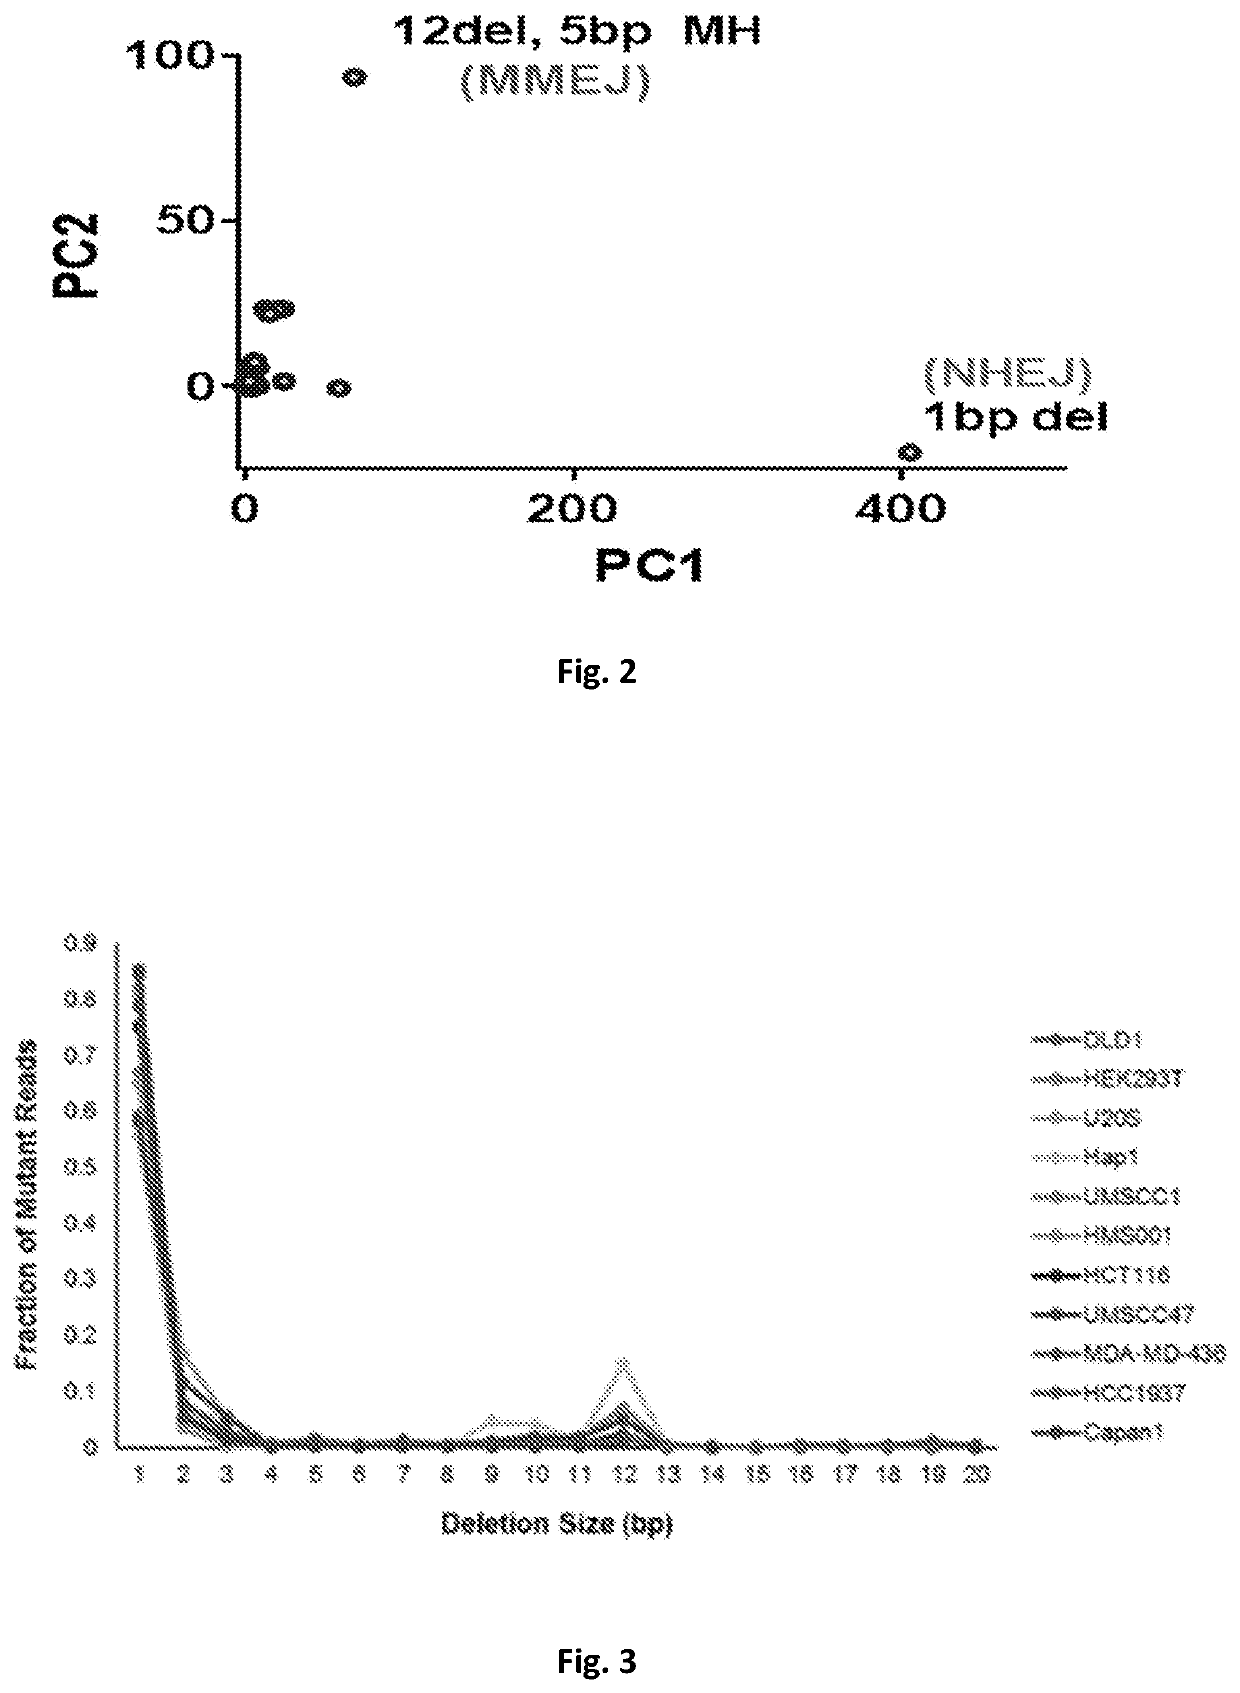
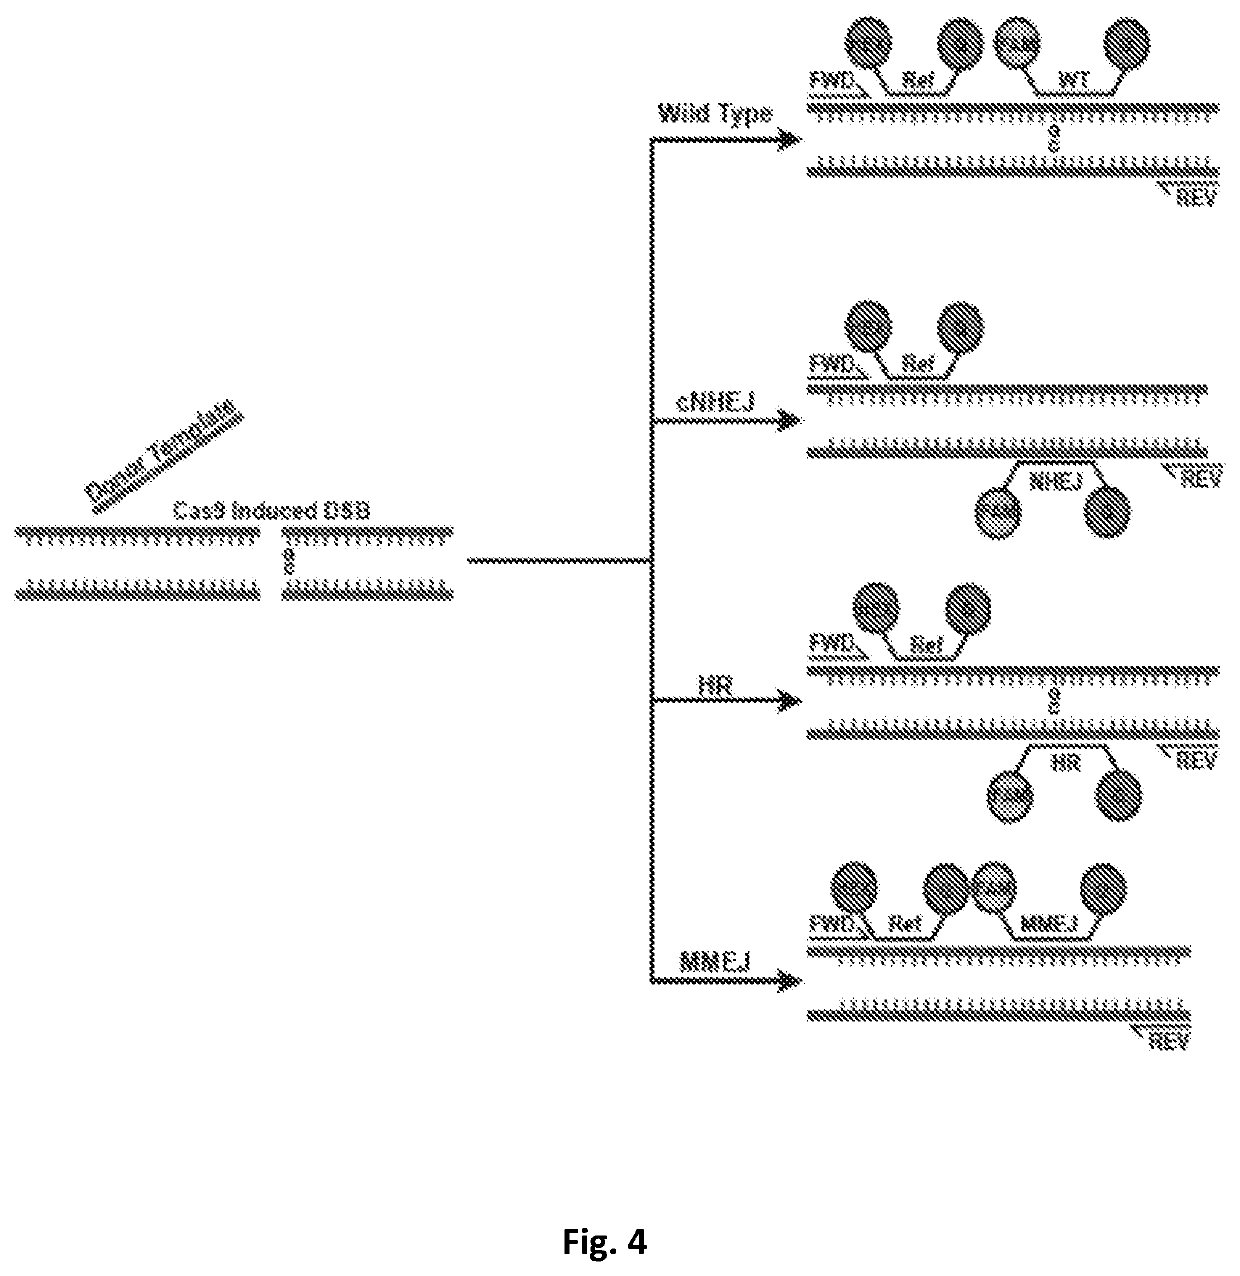
The present invention relates to DNA signatures that are characteristic of DNA that has been repaired in a cell by double strand break repair (DSBR) and that furthermore are characteristic of the specific cellular mechanism used to repair the DNA—such as homologous recombination (“HR”), non-homologous end joining (“NHEJ”), or microhomology-mediated end-joining (“MMEJ”). The present invention provides methods for identifying such DNA signatures, and also provides certain identified DNA signatures that are characteristic of DNA repair by HR, NHEJ, or MMEJ. The present invention also provides various methods and compositions that can be used to determine the presence of such DNA signatures in the genomes of living cells.
Owner:MEMORIAL SLOAN KETTERING CANCER CENT
A scalable robot torso and bionic quadruped robot
ActiveCN111496819BImprove obstacle performanceImprove athletic abilityManipulatorVehiclesPhysical medicine and rehabilitationLegged robot
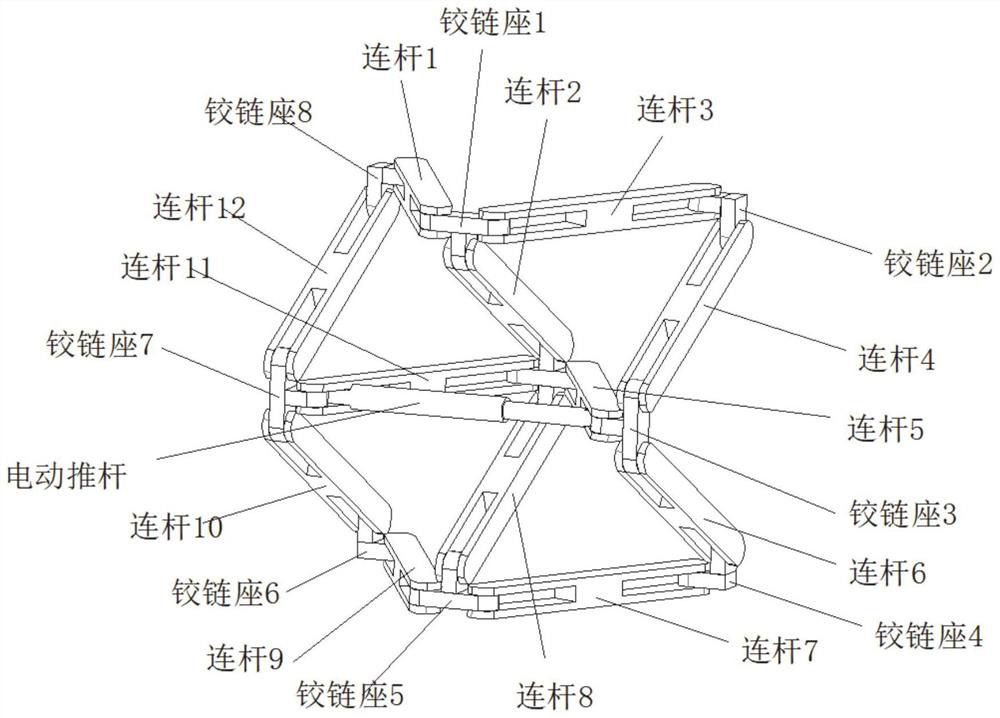
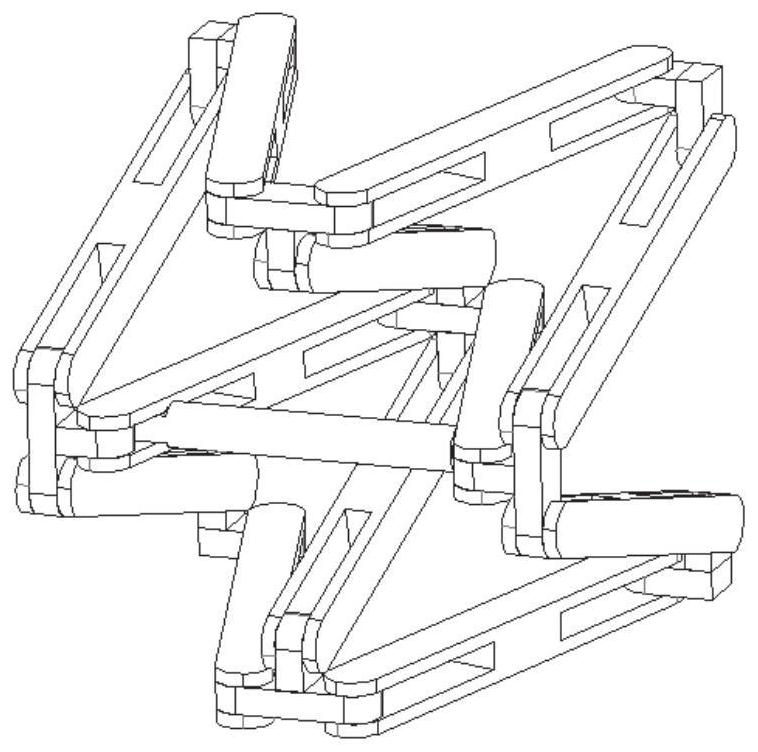
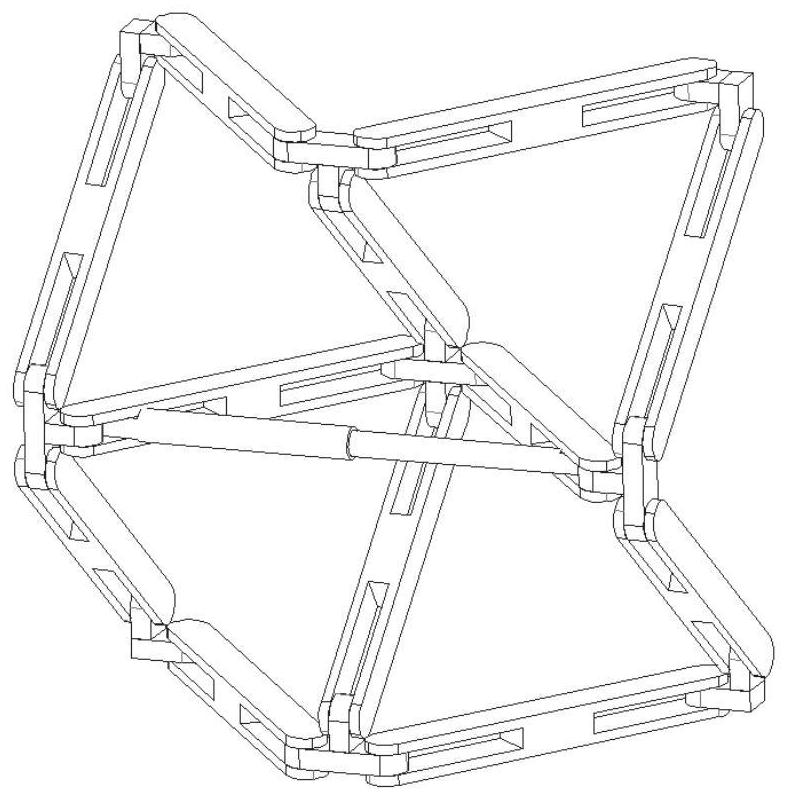
The invention discloses a scalable robot trunk and a bionic quadruped robot, comprising: a trunk link and an annular metamorphic mechanism; the trunk link connects two structurally symmetrical annular metamorphic mechanisms; the annular metamorphic mechanism consists of A plurality of first connecting rods are movably connected head-to-tail by the first connecting piece, and the second connecting rod is connected at the junction of every two first connecting rods, and only one end of each first connecting rod is connected with the second connecting rod, so The second connecting rods are movably connected through the second connecting piece; the telescopic rod is connected between the two second connecting rods in the center symmetrical position of the annular metamorphic mechanism. The present invention adopts a structurally symmetrical foldable metamorphic mechanism, two metamorphic mechanisms are connected through a trunk link to form a robot trunk, and each metamorphic mechanism adjusts the radial dimension of the robot trunk through a telescopic rod; the leg mechanism and the trunk Telescopic motion coupling, through the scaling and deformation of the torso, the distance between the legs of the robot, the height of the torso from the ground, etc. can be adjusted.
Owner:SHANDONG UNIV
Secreted neural apoptosis inhibiting proteins
A novel neuroprotectant was identified by microarray analysis that is differentially expressed between the ventricular zone and the cortex of human adult and fetal brain. The secreted protein antagonizes Wnt action in Xenopus embryos. Methods are described for modulating free radical neurotoxicity by contacting cells with the protein, treating neuronal diseases associated with free radical-mediated cell death by administering the protein, determining neuroprotective genomic targets associated with select free radical toxicity pathways by screening with the protein and using the protein to identify other compounds that modulate the biological activity of the secreted protein and the cell machinery that reacts to the secreted protein.
Owner:AVENTIS PHARMA INC
Methods and compositions for screening molecular function comprising chimeric minimotifs
InactiveUS20170335316A1Microbiological testing/measurementDNA preparationBiological bodyGenetic Databases
Disclosed herein are novel compositions and methods for elucidating biological activity and detection of molecular function. The methods and compositions disclosed herein can comprise the use of one or more minimotifs and a minimotif database for integrating and coordinating orthogonal knowledge derived from a variety of technological endeavors to provide systemic models representing complex biological and molecular interactions ranging from individual cells to entire organisms. The methods and compositions disclosed herein can utilize information related to biometrics including protein / protein interaction, and gene / gene interaction for evaluating cellular functions and cellular mechanisms.


Owner:BOARD OF RGT NEVADA SYST OF HIGHER EDUCATION ON BEHALF OF THE UNIV OF NEVADA RENO
Human and murine stem-cell lines: models of endothelial cell precursors
ActiveUS9631178B2Easy to adaptGood curative effectMicrobiological testing/measurementArtificial cell constructsStem cell lineHuman cell
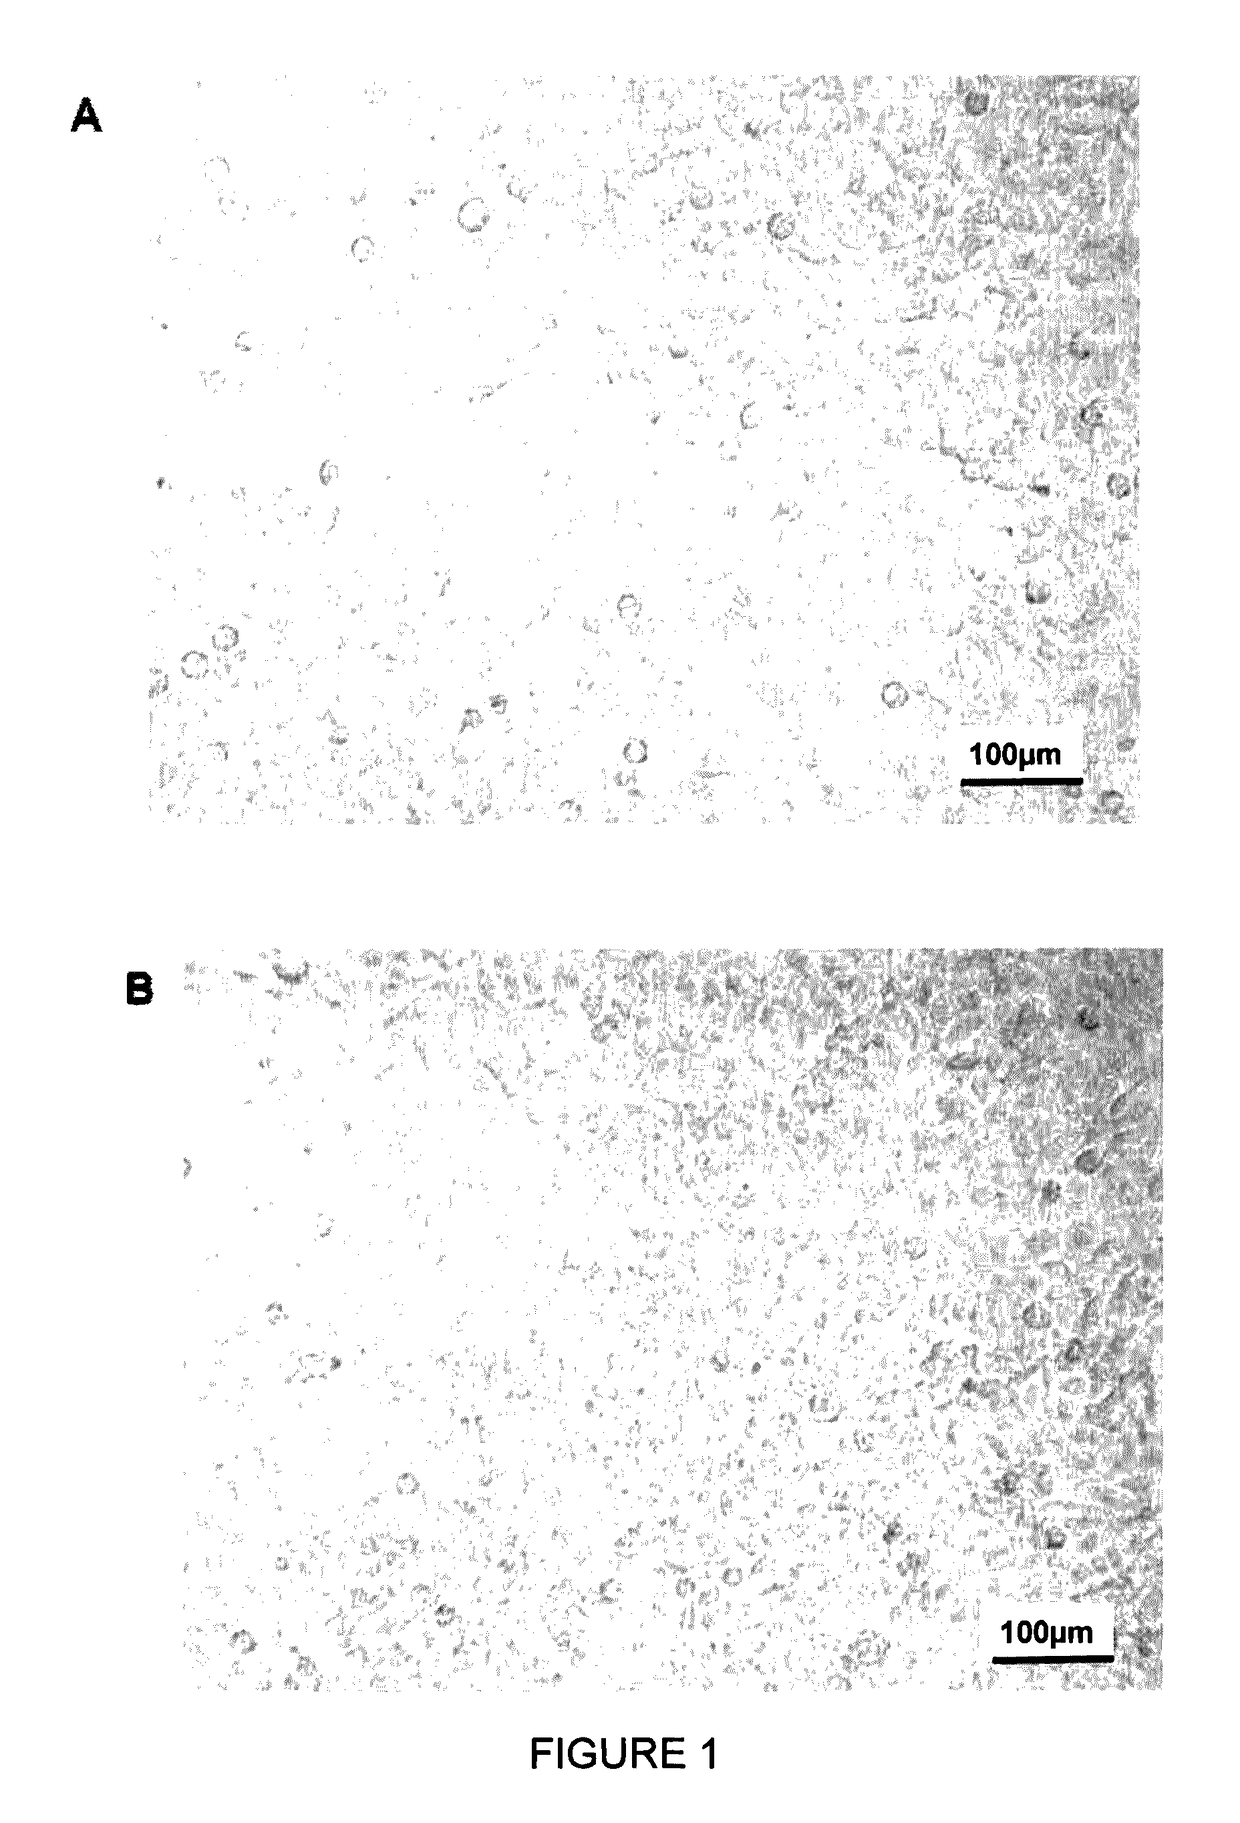
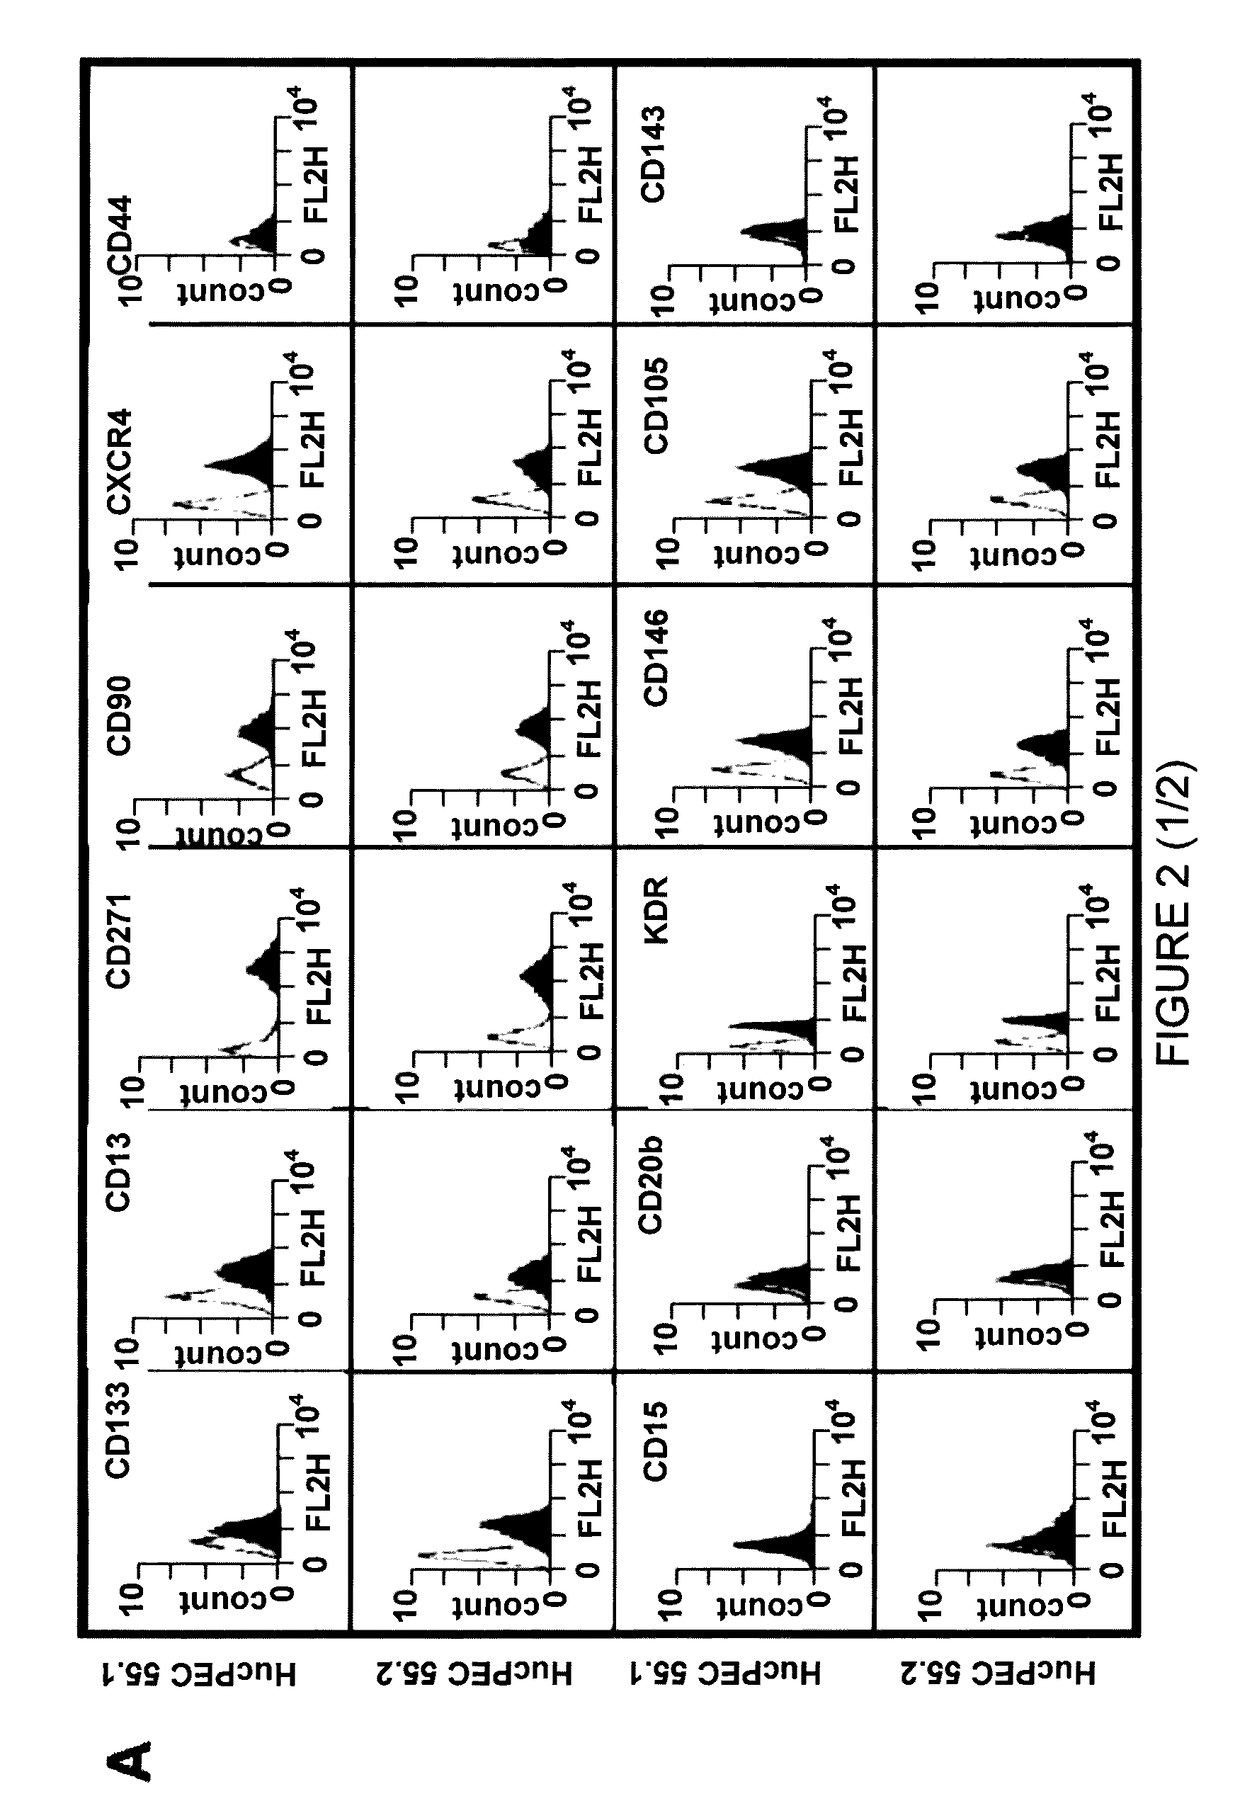
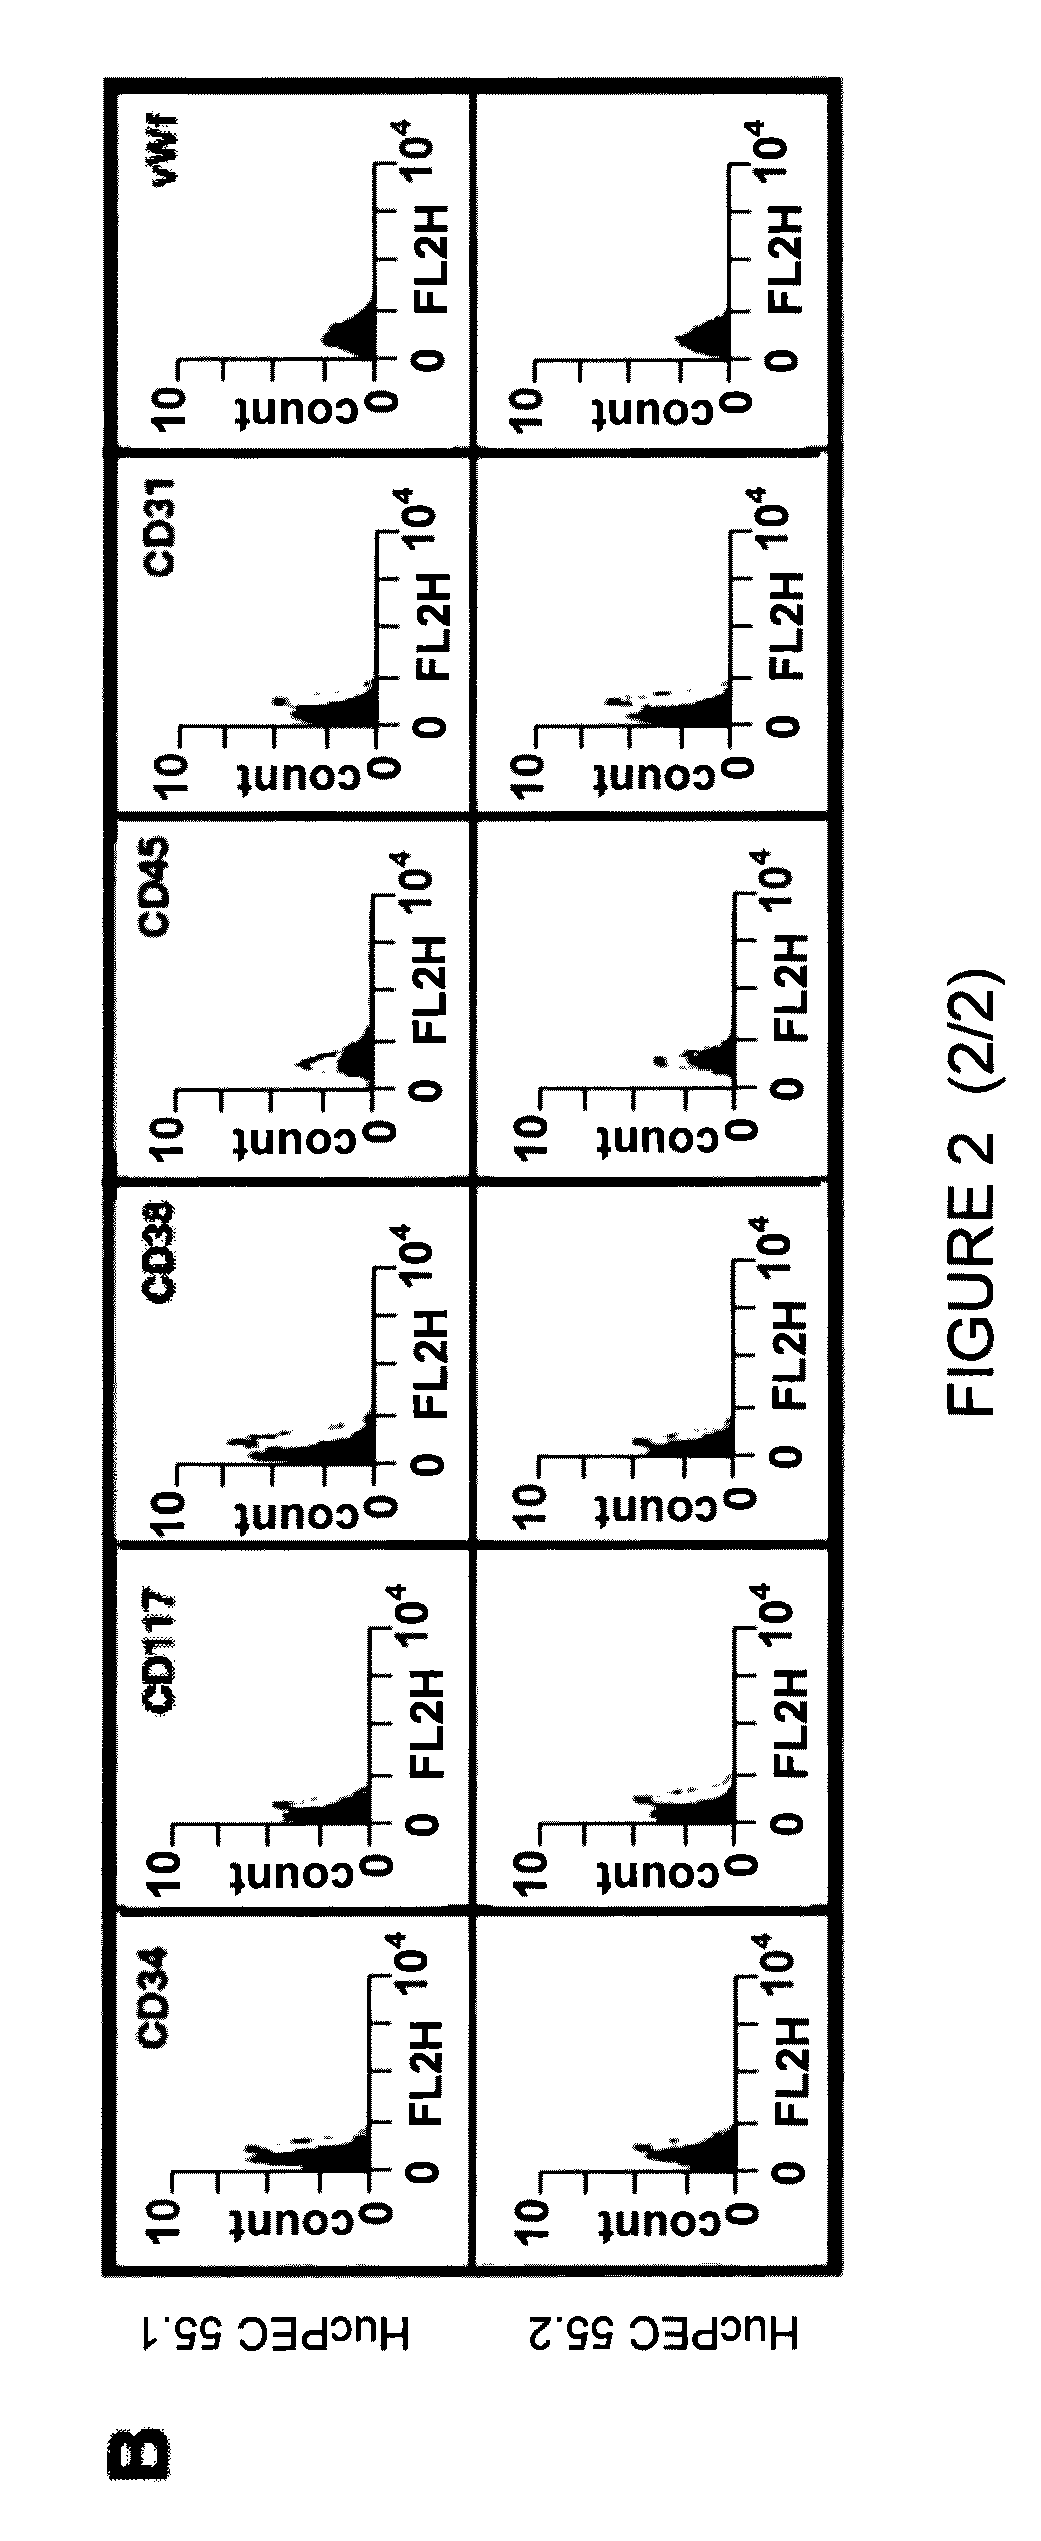
The present invention relates to isolated human cells that are precursors of endothelial cells other than embryonic stem cells, to isolated murine cells that are precursors of endothelial cells, and to methods using same. In particular, the present invention relates to established cell lines of isolated human cells that are precursors of endothelial cells other than embryonic stem cells and established cell lines of isolated murine cells that are precursors of endothelial cells. The present invention can be used in particular in the medical and / or veterinary fields, in particular in the field of therapeutics and / or in the field of studies of cellular mechanisms.
Owner:CENT NAT DE LA RECHERCHE SCI +1
Authentication for device with non-cellular access
PendingUS20260067679A1Key distribution for secure communicationSecurity arrangementAccess networkInternet privacy
Example embodiments of the present disclosure relate to authentication for device with non-cellular access. A first apparatus transmits, to a second apparatus, a registration request for a third apparatus. The registration request at least indicates that the third apparatus is accessing a network via a non-cellular mechanism. The first apparatus further receives, from the second apparatus, a first message indicating that the third apparatus is authenticated. Based on the receipt of the first message, the first apparatus further transmits security information to a fourth apparatus for establishing a connection between the third and fourth apparatuses. In this way, the third apparatus can be authenticated. In addition, secure connection can be established between the third and fourth apparatuses.

Owner:NOKIA TECHNOLOGIES OY