
Patents
Literature
51 results about "Fish locomotion" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Fish locomotion is the variety of types of animal locomotion used by fish, principally by swimming. This however is achieved in different groups of fish by a variety of mechanisms of propulsion in water, most often by wavelike movements of the fish's body and tail, and in various specialised fish by movements of the fins. The major forms of locomotion in fish are anguilliform, in which a wave passes evenly along a long slender body; sub-carangiform, in which the wave increases quickly in amplitude towards the tail; carangiform, in which the wave is concentrated near the tail, which oscillates rapidly; thunniform, rapid swimming with a large powerful crescent-shaped tail; and ostraciiform, with almost no oscillation except of the tail fin. More specialised fish include movement by pectoral fins with a mainly stiff body, as in the sunfish; and movement by propagating a wave along the long fins with a motionless body in fish with electric organs such as the knifefish.
Individual mode-based fishway fish passing simulation method
ActiveCN110359415APredict the fish effectAchieve fish effectBarrages/weirsClimate change adaptationRheotaxisFrequency data
The invention relates to an individual mode-based fishway fish passing simulation method. The individual mode-based fishway fish passing simulation method comprises the following steps: acquiring fishswimming ability data; acquiring fish rheotaxis frequency data; acquiring fish hobby flow speed data; establishing a simulated fishway hydrodynamic model; establishing an individual mode-based fish motion mathematical model; and acquiring fish upstream passing fishway process. According to the individual mode-based fishway fish passing simulation method, the effect of fish upstream passing fishway in the fishway is predicted, the fishway hydrodynamic model is established, the flow field frequent change condition in the fishway is simulated, the fish individual swimming ability, rheotaxis frequency and hobby flow speed range are acquired according to experiments, an individual mode-based fish motion model id established on the basis, motion of the fish individuals in the flow field is simulated, the model is coupled with the fishway hydrodynamic model, motion simulation of the fish individuals in the fishway is realized, basis is provided for estimation on the fishway fish passing effect, and prediction on the fishway fish passing effect is realized by the established mathematic model in an intuitive mode.


Owner:CHINA INST OF WATER RESOURCES & HYDROPOWER RES
Eel-like underwater multi-freedom-degree robot
InactiveCN105171722ANot affectedReduce disturbanceProgramme-controlled manipulatorUnderwater equipmentUnderwaterThree-dimensional space
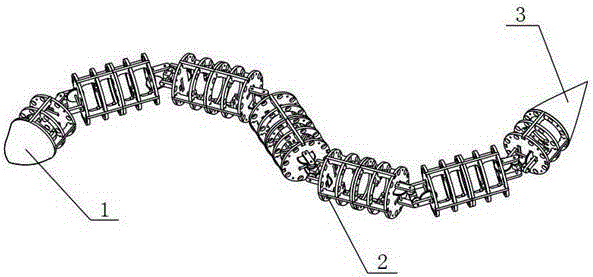
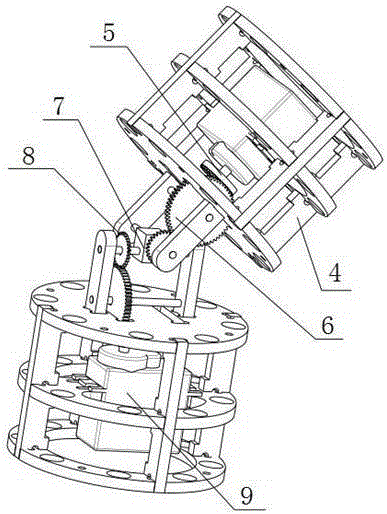
The invention relates to an eel-like underwater multi-freedom-degree robot. The robot is mainly composed of a head, cross structures, steering engines, a control panel and a tail, wherein the cross structures can rotate freely in the three-dimensional space, the body of the robot is composed of the multiple cross structures, one cross structure is driven by two steering engines, and the rotation of all the steering engines is controlled by the control panel so as to achieve forward movement, backward movement, pivot steering, upward swimming and downward swimming of the robot. The robot is ingenious in structural design, can well move in the way an eel does, has high mobility underwater, can work continuously for a long time, is suitable for underwater detection, pipeline overhauling and the like, and has great potential in both military use and civil use.
Owner:冯亿坤
Motion control method for multi-joint bionic machine fish
InactiveCN1595312AMotorized swimming controlFlexible swimming controlComputer controlAdaptive controlEngineeringMotion control
It is multiple-joint bionic machine fish move control method, which comprises the following: to control the speed of the machine fish straight moving through adjusting the swing frequency of the joints; to control the machine fish direction through exerting different joint excursion. This invention provides the theory design of the multiple-joint machine fish with preference and realizes the moving flexible control and can be applied in design of underwater aircraft, underwater exploration, underwater saving, underwater device maintenance and inspect and defense of the sea domain.


Owner:INST OF AUTOMATION CHINESE ACAD OF SCI
Fish counting device, fish counting method, fish count prediction device, fish count prediction method, fish counting system, and fish count prediction system
Provided are a simple fish counting device, fish counting method, fish count prediction device, fish count prediction method, fish counting system, and fish count prediction system. The fish counting device is characterized in that it includes: a measurement image acquisition means (11) that acquires multiple measurement images over time for a measurement subject region in a passage region through which a fluid containing fish passes; a fish position acquisition means (21) that acquires the positions of the fish for each of the multiple measurement images; a fish line-of-movement calculation means (22) that, on the basis of the positions of the fish in the multiple measurement images, calculates the line of movement for the fish, that is, the trajectory along which the fish are moving; and a fish counting means (23) that, on the basis of the lines of movement of the fish in the multiple measurement images, counts the number of fish.


Owner:NEC SOLUTION INNOVATORS LTD
Bionic flapping wing propulsion test platform
InactiveCN110435926AHigh precisionIncrease the number of groupsAircraft components testingIndependent motionFlapping wing
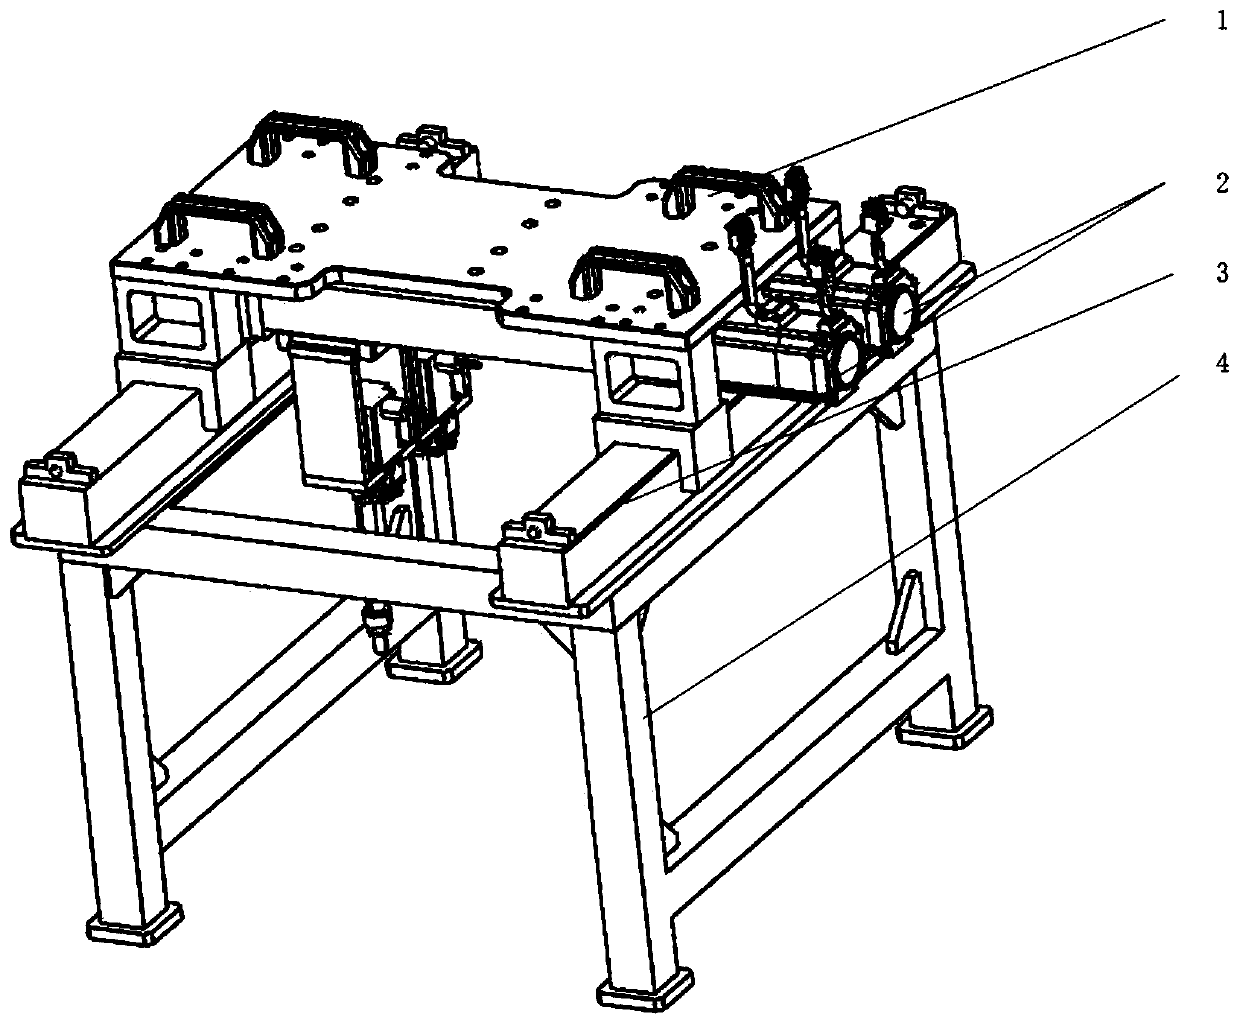
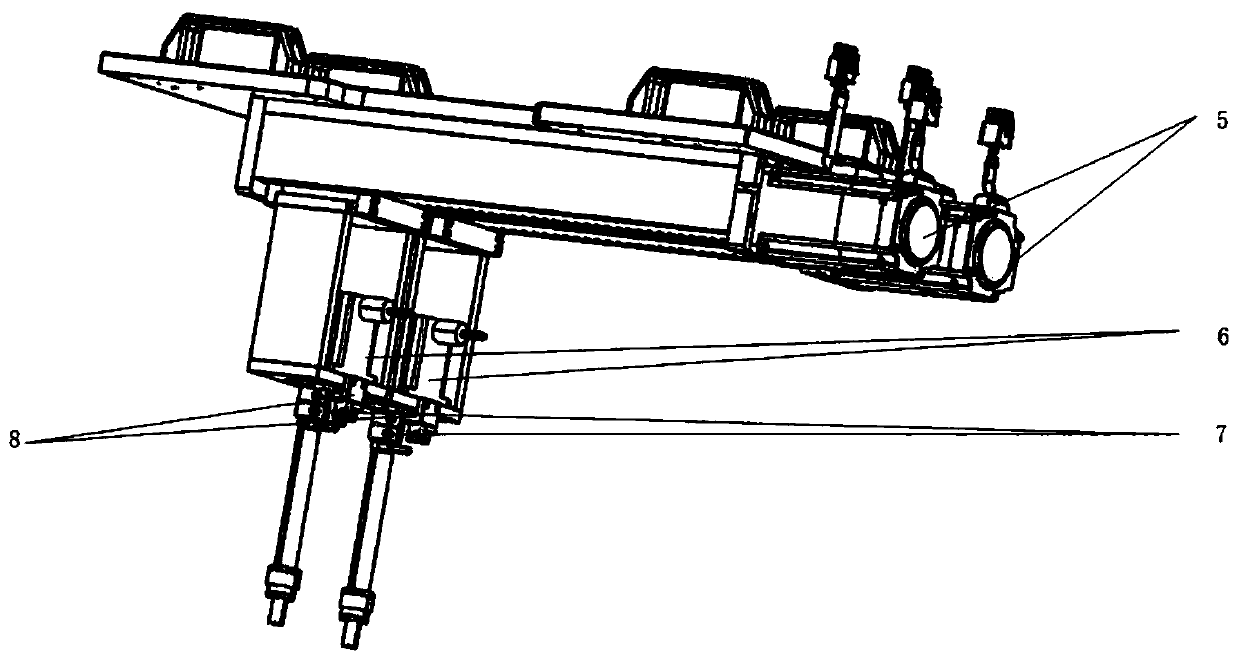
The invention discloses a bionic flapping wing propulsion test platform and belongs to the field of bionic tests. The bionic flapping wing propulsion test platform comprises two motion modules, two air floating guide rails and an air floating guide rail bracket; the air floating guide rail bracket is used for supporting the whole test platform, and the two air floating guide rails are fixed to twoends of the air floating guide rail bracket in parallel; the two ends of the motion module are respectively and slidably connected with the two air floating guide rails, so that horizontal translation and rotation of bionic flapping wings are achieved; the two motion modules are used for achieving the flapping wing motion of an imitation ray; each motion module comprises two stepping motors for controlling horizontal translation and rotation of the clamping the flapping wings, so that independent motion of single motion module and coordinated motion of multiple motion modules are achieved; the movement of the ray can be simulated more realistically, and the moving part is supported through the air floating guide rails, so that the free movement of the test platform in the propelling direction is achieved, and the precision of a whole propelling device is improved; and when the bionic flapping wing propulsion test platform is suitable for other bionic flapping wing propulsion experiments, the experimental effect can be achieved by directly increasing the number of the motion modules.
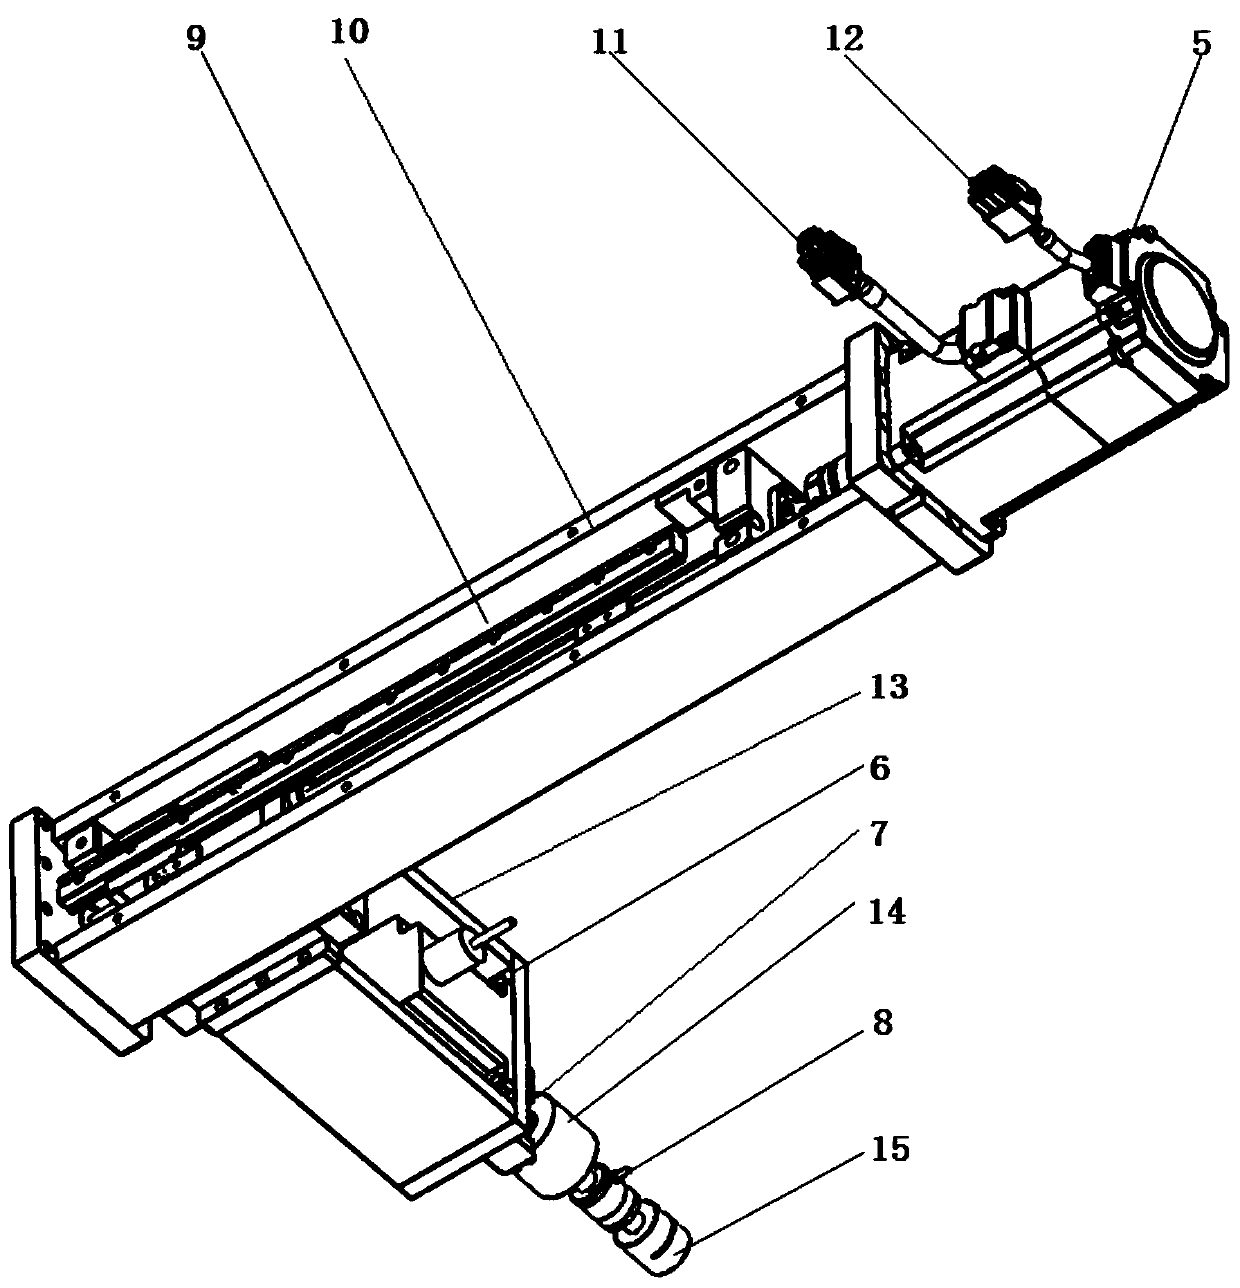
Owner:NORTHWESTERN POLYTECHNICAL UNIV
Control method for non-semidiameter turn of bionic machinery fish
InactiveCN101219708AChange does not affectRealize in-situ photographyAquatic toysPropulsive elements of non-rotary typeAutomatic controlControl signal
The invention relates to a method for controlling no-radius turning of a biomimetic robot fish, relating to an automatic control field. Taking a centroid of the robot fish as an origin, the invention establishes a kinematics model of the robot fish; the robot fish is articulated and a rotation angle of each joint is calculated according to the kinematics model; a control circuit sends a control signal to drive the robot fish to swing from a fishtail joint; a force couple is formed through thrust force F of water, which realizes the no-radius turning of the biomimetic robot fish by taking the centroid as the origin. Through a reaction force of the water to the robot fish, no-radius turning of the robot fish around the centroid is realized. By adopting the method of the no-radius turning of the biomimetic robot fish of the invention, in-situ no-radius turning of the biomimetic robot fish can be realized; when changing direction, position is not affected so that the robot fish can be more flexible. The method, which can well control the change of directions at a certain position, can realize underwater in-situ detection and in-situ photography of underwater archaeology.


Owner:CHONGQING UNIV OF POSTS & TELECOMM
Three-joint structure of robotic fish
ActiveCN107380386AHigh freedom of movementFit closelyClimate change adaptationPropulsive elements of non-rotary typeMarine engineeringStructural engineering
The invention discloses a three-joint structure of a robotic fish. A plurality of slave driving joints are arranged between a first main driving joint and a second main driving joint and between the second main driving joint and a third main driving joint in a length direction of a fish body; each slave driving joint comprises a supporting ring, a vertebra hinge and a vertebra hinge connecting rod; and the vertebra hinges of the plurality of slave driving joints are end to end to form a vertebral column of the robotic fish. The three-joint structure of the robotic fish has the advantages that the freedom degree of motion of the robotic fish is increased, the robotic fish swims to fit the fish motion curve, the robotic fish swims like a real fish and the robotic fish swims without joint disconnection phenomenon; the burden of a driving rod is reduced by using the slave driving joints so that the breakage of the driving rod is avoided.


Owner:HOHAI UNIV
Biomimetic robot fish and control method thereof
InactiveCN109956016AFlexible controlBionic effect is goodPropulsion power plantsPropulsive elements of non-rotary typeControl systemEngineering
The invention relates to a biomimetic robot fish. The biomimetic robot fish comprises a head and a tail, wherein the head is internally provided with a control system; the tail comprises tail fins andis internally provided with two driving components; the two driving components are symmetrically arranged along the width direction of the tail; the control system separately controls swing amplitudeand frequency of each driving component according to the amplitude and the frequency of voltage, and further controls the motion of the biomimetic robot fish. According to the biomimetic robot fish provided by the invention, the control system separately controls the swing amplitude and frequency of each driving component according to the amplitude and the frequency of the voltage, so that higherflexibility in control is realized and a better biomimetic effect is realized.


Owner:TONGJI UNIV
Three-joint design method for robot fish based on improved fish body wave equation
ActiveCN107444598ALarge turning momentImprove propulsion performancePropulsive elements of non-rotary typeBionicsGoverning equation
The invention discloses a three-joint design method for a robot fish based on an improved fish body wave equation and provides a theoretical basis for the study of the robot fish. The improved fish body wave equation is derived under the consideration of swaying of a fish head. The three-joint design method is designed and calculated based on the improved fish body wave equation, so that the swimming of the robot fish designed according to the three-joint design method is more in accordance with motion laws of real fishes. By controlling a governing equation of driving joints, the bionic robot fish is capable of quickly steering and obtaining a greater turning moment, thereby realizing good propulsion performance. A three-joint structure is provided with the driving joints and driven joints and vertebra hinges of the driven joints are designed according to vertebrae of the real fishes, thereby increasing the freedom of motion of the robot fish, allowing the swimming of the robot fish to be better in accordance with the motion curve of the real fishes and more similar to the real fishes, and avoiding the disjunction during the swimming of the robot fish.


Owner:HOHAI UNIV
Bionic flexible arm drive type submersible
ActiveCN108622347AReduce running noiseUnderwater vesselsUnderwater equipmentElectricityOcean exploration
The invention relates to a bionic flexible arm drive type submersible and belongs to the technical field of diving robots. The bionic flexible arm drive type submersible comprises a watertight body shell, a control unit and a power source unit which are installed in an inner cavity of the watertight body shell, and a buoyancy adjusting unit and a power unit which are controlled by the control unit; the power unit comprises more than three flexible drive arms installed at the tail end of the watertight body shell; and each flexible drive arm comprises a flexible arm body and an actuator installed in the flexible arm body and used for driving the flexible arm body to bend and deform, and each actuator comprises an electrical deformation element. The flexible arm bodies driven by the electrical deformation elements are adopted as the flexible drive arms, so that the motion mode of an octopus is simulated, noise generated in the operation process is effectively reduced, the invisibility ofthe whole submersible is improved, and the submersible can be widely applied to the fields such as ocean exploration.


Owner:CHINA UNIV OF PETROLEUM (EAST CHINA) +1
Method for precisely controlling C-turn movement of robotic fish
ActiveCN107505838ATurn fasterLarge turning momentPropulsive elements of non-rotary typeAdaptive controlKinematics equationsBionics
The present invention discloses a method for precisely controlling the C-turn movement of a robotic fish. According to the method, analysis is performed on the basis of the posture curve cluster of an existing bionic robot fish C-turn, so that the process of the C-turn can be divided into a contraction phase and a release phase; with the symmetry center of the body of the robotic fish adopted as an object, so that the kinematic equation of the C-turn can be obtained, and the tail movement posture curve of the bionic robot fish at a certain time point is drawn according to the kinematic equation, a posture curve at each time point is obtained by fitting k rigid joints, and the motion control equations of the joints are obtained through numerical approximation and the minimum error method; and therefore, the kinematic equations of the joints provide a kinematic model for research and analysis of the movement posture of the robotic fish, enable the bionic robotic fish to have a rapid turning ability, enable the robotic fish to obtain a higher turning moment, and finally can make the robotic fish have good propulsion performance.


Owner:HOHAI UNIV
Method and device for extracting perception and response relation of fish to water flow form
PendingCN114692895AEasy to reproduce the state of water flowFlow state is not restrictedFluid pressure measurementCharacter and pattern recognitionMarine engineeringWater flow
The invention relates to the technical field of water conservancy and hydropower engineering environmental protection, in particular to a method and device for extracting the perception and response relation of fishes to water flow forms. Comprising the following steps that S1, according to different lengths of target fishes, cylinders, blocks or partition plates of different sizes are arranged to serve as obstacles, and various water flow forms possibly encountered by fish bodies during swimming are manufactured in a water tank; s2, recording pressure data measured by the target fish in the swimming process through distributed flexible film pressure sensors on the surface of the fish body; s3, establishing an artificial neural network model of the motion parameters of the target fish and the measured pressure data through a machine learning method; and S4, predicting fish motion parameters in a new flow field environment by using the artificial neural network model established in the step S3, and continuously updating, iterating and perfecting the artificial neural network model by using new measured data.


Owner:NANTONG UNIVERSITY
Long-distance transportation method applicable to live sea bass
ActiveCN104381156ARealize commercial transportationBroaden sales channelsClimate change adaptationPisciculture and aquariaAquaculture industryHigh density
The invention provides a long-distance transportation method applicable to live sea bass. The method comprises the following steps: selection and pretreatment of sea bass; arching of the sea bass: a step of providing an arching device which comprises a fish body belt and a fishtail belt that are intersected and fixed together, allowing the fishtail belt to wind around the fishtail of the sea bass for one circle and then to be fixed at the fishtail part and enabling one end of the fish body belt to pass through the mouth and the lower edge of the operculum of the sea bass and then to be fixed with the other end, thereby enabling the sea bass to be arched; encasement; and transportation. According to the invention, no drug is used, and only physical control means are adopted; the sea bass is arched by using the arching device and the gills of the sea bass are exposed to water, so the sea bass is forced to expose the respiratory organ; meanwhile, movement of the arched sea bass is limited, so mutual damage of the sea bass caused by leaping of the sea bass can be prevented and oxygen consumption of the sea bass is reduced; high-density transportation can be realized; and a high survival rate is obtained. The method is simple to operate, is natural and environment-friendly and can realize commercial transportation of live sea bass, so marketing channels of sea bass are broadened; the commodity value of sea bass is improved; and sound development of the whole sea bass aquaculture industry is promoted.


Owner:珠海市斗门区河口渔业研究所
Determining method and system for fin-propulsive robotic-fish movement energy consumption
ActiveCN107818210ASports energy consumption is simple and fastCalculation is simple and fastDesign optimisation/simulationSpecial data processing applicationsSimulationEnergy consumption
The invention discloses a determining method and system for fin-propulsive robotic-fish movement energy consumption. The method includes the steps that the swinging deflection angle, the swinging amplitude and the swinging frequency of a robotic-fish tail fin are obtained; an energy-consumption model of a robotic fish is determined; according to the swinging deflection angle, the swinging amplitude and the swinging frequency of the robotic-fish tail fin and the energy-consumption model of the robotic fish, robotic-fish movement energy consumption is calculated. According to the determining method and system for fin-propulsive robotic-fish movement energy consumption, a calculation model of robotic-fish movement energy consumption is provided, the movement energy consumption model is relevant to the swinging deflection angle, the swinging amplitude and the swinging frequency of the robotic-fish tail fin, and according to the movement energy consumption model and the swinging deflectionangle, the swinging amplitude and the swinging frequency of the robotic-fish tail fin, movement energy consumption of the robotic fish can be calculated. The determining method and system have the advantages of being easy, fast and convenient to calculate and high in accuracy.


Owner:CHENGDU UNIV OF INFORMATION TECH
Robot fish with three-joint structure
ActiveCN107444597AHigh freedom of movementReduce loadPropulsive elements of non-rotary typeMarine engineeringStructural engineering
The invention discloses a robot fish with a three-joint structure. A plurality of driven joints are arranged along the length direction of a fish body and among driving joints. Each of the driven joints comprises a supporting ring, a vertebra hinge and a vertebra hinge connecting rod. The supporting rings are provided with clamping grooves for fixing the vertebra hinges. The vertebra hinges of the plurality of driven joints are in end-to-end connection with each other to form a vertebra of the robot fish. Three load-bearing supporting rods which are 4 mm in diameter are arranged inside a mouth part of a fish head and at the anterior 1 / 3 of the mouth. The robot fish provided by the invention is provided with the driving joints and the driven joints, thereby increasing the freedom of motion of the robot fish, allowing the swimming of the robot fish to be better in accordance with the motion curve of real fishes and more similar to the real fishes, and avoiding the disjunction during the swimming of the robot fish. The driven joints reduce the load of driving rods and avoid the breaking of the driving rods. The load-bearing supporting rods arranged inside the mouth of the fish head increase the compressive strength of the fish head, thereby avoiding the damage of the fish head.


Owner:HOHAI UNIV
Fish feeding method, system and equipment based on image processing and storage medium
PendingCN113592896ASolve technical problems of feedingPrecise feeding behaviorImage enhancementImage analysisImaging processingFishery
The embodiment of the invention relates to the technical field of image processing, and discloses a fish feeding method, system and device based on image processing and a storage medium. The method comprises the steps of firstly obtaining a current fish motion image; performing target tracking according to the current fish motion image to record a fish motion track; determining fish motion parameters according to the fish motion track; determining a fish hunger state according to the fish motion parameters; the current feeding behavior is determined according to the fish hunger state, and the fish is fed with feed. Obviously, according to the embodiment of the invention, the current feeding behavior can be accurately determined by taking the current actual behavior of the fish as a parameter, so that a feasible accurate feeding strategy can be flexibly provided for different cultured fishes in different culture environments, the feeding behavior is more intelligent and more accurate, and the feeding efficiency is improved. The technical problem that fish feeding cannot be conducted accurately is solved.


Owner:CHINA AGRI UNIV
Fish culture monitoring method based on multi-dimensional data source, medium and equipment
The invention discloses a multi-dimensional data source fish culture monitoring method, medium and equipment, and the method comprises the steps: collecting original video information and original water quality information, and carrying out image enhancement processing and multi-scale feature fusion processing based on a space-time attention mechanism through employing a self-adaptive color cast correction algorithm, obtaining first video information and first water quality information; fish movement track features and group three-dimensional distribution features are extracted from video information, and a dynamic incidence matrix is constructed through a graph neural network in combination with water quality information. Fine-grained behavior classification is realized by using an improved space-time Transform model, and deep correlation between behaviors and water quality parameters is established through a cross-modal attention mechanism. And constructing a dynamic evaluation model based on the associated information to realize multi-level early warning, performing distributed analysis by adopting a federal learning framework, and generating a comprehensive monitoring report. According to the invention, multi-dimensional accurate monitoring and intelligent early warning in the breeding process are realized, and the scientificity and timeliness of breeding management are significantly improved.

Owner:FUJIAN MINWELL IND CO LTD +2
Fish migration trajectory tracking method
The invention proposes a fish migration trajectory tracking method, and relates to the technical field of fish trajectory tracking, and the method comprises the steps: S1, constructing a deep learning model which comprises a multi-branch feature extraction network and a trajectory segment encoder; s2, training a deep learning model by utilizing the fish video data set, and optimizing model parameters by adopting a comparative learning strategy and regularization constraint to obtain a fish multi-target tracking model; s3, processing a to-be-analyzed fish video by using the fish multi-target tracking model, and performing trajectory tracking of fish individuals through a multi-layer matching strategy to obtain a complete fish motion trajectory; and S4, calculating the main direction angle of the fish movement track through principal component analysis, and judging the migration direction according to the included angle between the main direction angle and the river direction angle so as to track the migration of the fish. According to the method, the technical problems that an existing fish trajectory tracking method is not accurate enough in feature representation in a complex underwater environment, a time sequence association strategy is incomplete, and trajectory continuity and consistency in long-time tracking are insufficient can be solved.

Owner:WATER ENG ECOLOGICAL INST CHINESE ACAD OF SCI
Fish behavior identification method and device
ActiveCN119625816AHigh precisionImprove efficiencyClimate change adaptationCharacter and pattern recognitionFeature extractionFishery
The invention provides a fish behavior identification method and device. The method comprises the following steps: acquiring a fish motion image; inputting the fish motion image to the target detection model to obtain a fish target detection result; analyzing a fish target detection result to obtain a fish tracking trajectory; analyzing the fish tracking trajectory to obtain fish motion features; and inputting the fish motion features to the behavior recognition model to obtain a fish behavior recognition result. According to the fish behavior recognition method and device, the model framework integrating the motion feature extraction function and the behavior state recognition function is constructed, the defects that in the prior art, parameters are complex and recognition is difficult in fish behavior recognition can be overcome, and the fish behavior recognition precision and efficiency are improved.

Owner:CHINA AGRI UNIV
Fish Multi-Target Tracking Method for Land-Based Industrial Recirculating Aquaculture Scenarios
The present invention relates to the field of computer vision technology, and specifically to a method for multi-object tracking of fish in the scenario of land-based industrialized recirculating aquaculture. First, the present invention obtains the fish movement video and light intensity of a land-based industrialized recirculating aquaculture farm. Secondly, video frames that meet preset conditions are selected from the fish movement video as reference frames. Then, based on the fish movement video and light intensity, video frame features are extracted, and a video frame adjustment coefficient is generated in combination with the reference frames. Then, an adaptive adjustment model for fish movement video frames is constructed according to the video frame adjustment coefficient to adaptively adjust the fish movement video frames to obtain a standard fish movement video. Then, a fish multi-object tracking model is constructed to perform multi-object tracking of fish on the standard fish movement video to obtain fish movement trajectories. Finally, according to the fish movement trajectories and the standard fish movement video, a fish health detection model is constructed to detect the health status of each fish in the standard fish movement video.

Owner:NANJING CHAOS INFORMATION TECH CO LTD
A three-joint design method for robotic fish based on improved fish body wave equation
ActiveCN107444598BLarge turning momentImprove propulsion performancePropulsive elements of non-rotary typeBionicsEngineering
The invention discloses a three-joint design method for a robot fish based on an improved fish body wave equation and provides a theoretical basis for the study of the robot fish. The improved fish body wave equation is derived under the consideration of swaying of a fish head. The three-joint design method is designed and calculated based on the improved fish body wave equation, so that the swimming of the robot fish designed according to the three-joint design method is more in accordance with motion laws of real fishes. By controlling a governing equation of driving joints, the bionic robot fish is capable of quickly steering and obtaining a greater turning moment, thereby realizing good propulsion performance. A three-joint structure is provided with the driving joints and driven joints and vertebra hinges of the driven joints are designed according to vertebrae of the real fishes, thereby increasing the freedom of motion of the robot fish, allowing the swimming of the robot fish to be better in accordance with the motion curve of the real fishes and more similar to the real fishes, and avoiding the disjunction during the swimming of the robot fish.


Owner:HOHAI UNIV
a fish feeding device
InactiveCN105191847BReduce wasteDischarge volume can be adjustedClimate change adaptationPisciculture and aquariaEngineeringBuoy
The invention provides a fish feeding device, comprising a barrel and a buoy arranged on the barrel, wherein the barrel is internally provided with a cavity for placing fish food, and is also provided with a plurality of through holes; the barrel comprises an outer barrel and an inner barrel inserted into the outer barrel; an opening of the inner barrel is provided with a turned edge used for facilitating rotation; friction grains are arranged between the inner barrel and the outer barrel, and generate friction force, and when power generated when the turned edge is rotated is greater than the friction force, the inner barrel and the outer barrel can mutually rotate; the outer barrel and the inner barrel are provided with through holes which are corresponding in positions; the buoy is connected onto the outer barrel in a sleeved way and can slide up and down relative to the outer barrel; each of the outer barrel and the inner barrel is provided with a semicircular barrel bottom. The fish feeding device has the beneficial effects of effectively alleviating pollution of the fish food to water in a fish tank, reducing the waste of the fish food, adjusting a discharge rate of the fish food, increasing the exercise amount of fish, being low in manufacturing cost, being made of transparent plastic and facilitating watching.


Owner:平潭台奖水产养殖有限公司
Method for monitoring motion behaviors of estuary offshore fishes based on unmanned aerial vehicle
According to the method for efficiently monitoring the motion behaviors of the fishes near the estuary shore based on the unmanned aerial vehicle, by combining the unmanned aerial vehicle high-resolution image technology, the video monitoring technology and the fish motion behavior analysis data processing algorithm, efficient and accurate monitoring of the motion behaviors and distribution of the fishes in the estuary area is achieved. Through data acquisition and accurate motion trail analysis, the method not only improves the monitoring efficiency, but also provides accurate data support for researching fish behaviors, is helpful to better understand the motion migration mode of fish in the estuary area, assesses the habitat quality, and improves the fish habitat quality. And an activity mode of influence of environment change on fish behaviors is monitored, so that a scientific basis is provided for ecological environment protection and fishery sustainable management measures in the near-shore of the estuary.

Owner:EAST CHINA SEA FISHERIES RES INST CHINESE ACAD OF FISHERY SCI
Fish classification screening method based on fusion of behavioristics and artificial intelligence
The invention belongs to the technical field of fish behavioristics analysis and aquaculture intelligence, and relates to a fish grading screening method based on fusion of behavioristics and artificial intelligence, which comprises the following steps: shooting to obtain a fish motion track image, respectively extracting 128 behavior characteristics of fish within a time period of 1 minute, and calculating the behavior characteristics of the fish according to the 128 behavior characteristics; generating behavioral characteristics of each fish at different time; a data matrix Lm + n (v) (b1, b2,..., b128) is established, a random forest model is utilized to calculate the prediction test result probability of each fish in each time period of 1 minute, specifications are determined, the fishes are identified as large-specification individuals and small-specification individuals accordingly, and an intelligent mechanical fish grading system is adopted to realize fish fry grading. According to the method, the labor cost of culture grading and the stress damage to the fishes caused by fishing anesthesia are reduced, an intelligent fishery solution is provided for economic fish fry culture, and a traditional culture mode is promoted to be transformed and upgraded to modernization and digitization directions.

Owner:OCEAN UNIV OF CHINA
A method for quantifying the effect of pulsed electric fields on fish behavior
ActiveCN119691383BDigital data information retrievalClimate change adaptationComputational physicsPulse electric field
The application provides a kind of quantification method for characterizing the influence of pulsed electric field on fish behavior, comprising: obtaining the behavior data of target fish under the influence of different electric field parameters;Marking the trajectory of fish movement, obtaining speed, acceleration, time and coordinate information;For the behavior data, obtain the coordinates of the sensing point of the fish, the coordinates of the turning point, the maximum acceleration before escaping the electric field and its corresponding coordinates, the maximum speed after escaping the electric field and its corresponding coordinates;Calculate the sensing distance, the turning distance, the maximum acceleration corresponding distance and the maximum speed corresponding distance, and the turning or passing situation as the characteristic parameters of fish behavior;Establish the correlation model between the pulsed electric field parameters and the characteristic parameters of fish behavior, and quantitatively analyze the influence of electric field parameters on fish behavior.The method of the application can effectively evaluate and optimize the electric field parameter setting of fish blocking electric fence by obtaining and analyzing the characteristic behavior data of fish in the electric field, and establishing the correlation model of characteristic behavior and electric field parameters.

Owner:CHANGJIANG RIVER SCI RES INST CHANGJIANG WATER RESOURCES COMMISSION
Method and device for recognizing fish behavior
ActiveCN119625816BClimate change adaptationCharacter and pattern recognitionFeature extractionFishery
The application provides a fish behavior recognition method and device, the method comprising: acquiring a fish motion image; inputting the fish motion image into a target detection model to obtain a fish target detection result; analyzing the fish target detection result to obtain a fish tracking trajectory; analyzing the fish tracking trajectory to obtain a fish motion feature; and inputting the fish motion feature into a behavior recognition model to obtain a fish behavior recognition result. The fish behavior recognition method and device can solve the defects of complex parameters and difficult recognition in the prior art by constructing a model framework integrating motion feature extraction and behavior state recognition functions, thereby improving the fish behavior recognition accuracy and efficiency.

Owner:CHINA AGRI UNIV
Live fish catching counting method and system based on image processing
The application discloses a kind of live fish catching counting method and system based on image processing, for real-time obtaining live fish video frame image set in culture net cage, and accurately count the species and quantity of cultured fish.The method comprises the following steps: real-time obtaining live fish video frame image set and the name of the species of cultured fish;Construct fish feature database;Extract fish feature information in each frame image;Compare the extracted features with the database, determine the species of fish and mark;Based on trajectory tracking algorithm, construct fish motion trajectory model;Analysis and statistics are carried out on the fish motion trajectory, and the quantity of each kind of fish is obtained.The application realizes automatic counting by using image processing technology, and provides more information through trajectory analysis.The method can improve the accuracy and efficiency of counting, and has important significance for aquaculture management and environmental monitoring.

Owner:SOUTH CHINA SEA FISHERIES RES INST CHINESE ACAD OF FISHERY SCI
A precision feeding system for fishery
ActiveCN117617168BData processing applicationsClimate change adaptationVisual technologyWater quality
The application discloses a kind of fishing precision feeding system, it is related to aquaculture technical field, including: water identification device, edge server, intelligent feeding device, water identification device, edge server, intelligent feeding device are sequentially connected;Water identification device is used to obtain fish movement containing video stream information and is sent to edge server through local area network;Edge server is used to identify and count target fish in video stream information through pre-trained YOLOv8 network, determine the real-time proportion of target fish in different regions, obtain the feed consumption data of different regions and send to corresponding intelligent feeding device;Intelligent feeding device is based on the feed consumption data received to complete feeding.The application uses deep learning computer vision technology, and more accurately feeds by the distribution of fish in each region;Through the way of intelligent precision feeding, fish feed is saved, and water pollution caused by excessive feeding is prevented.

Owner:BEIJING INST OF TECH
Fish detection methods, devices, systems and storage media
This invention discloses a fish detection method, apparatus, system, and storage medium, relating to the field of underwater detection technology. The fish detection method includes the following steps: inputting a set of fish keyframe images into a Gaussian Mixture Model (GMM) for moving target detection, obtaining GMM fish target bounding boxes; inputting the set of fish keyframe images into a YOLO neural network model for moving target detection, obtaining YOLO fish target bounding boxes; determining whether the GMM fish target bounding boxes and / or YOLO fish target bounding boxes are true fish target bounding boxes according to a preset judgment logic, and outputting the corresponding true fish target bounding boxes. Utilizing the high detection speed and accuracy of the YOLO neural network model, and integrating the GMM model to fully exploit the characteristics of fish moving target information, the fish target bounding box fusion judgment method effectively avoids false detections and missed detections, improves the model's detection accuracy, and achieves real-time and accurate detection of fish feeding intensity, feeding distribution, and other state information.


Owner:SOUTHERN MARINE SCIENCE & ENGINEERING GUANGDONG LABORATORY (ZHANJIANG)
Quantization method for representing influence of pulsed electric field on fish behaviors
ActiveCN119691383ADigital data information retrievalClimate change adaptationBehavioral dataMechanical engineering
The invention provides a quantification method for representing the influence of a pulsed electric field on fish behaviors. The method comprises the following steps: acquiring behavior data of target fish under the influence of different electric field parameters; marking a fish movement track, and obtaining speed, acceleration, time and coordinate information; aiming at the behavior data, acquiring induction point coordinates, turning point coordinates, the maximum acceleration before escaping from the electric field and corresponding coordinates thereof, and the maximum speed after escaping from the electric field and corresponding coordinates thereof; an induction distance, a turn-back distance, a distance corresponding to the maximum acceleration, a distance corresponding to the maximum speed and a turn-back or passing condition are calculated to serve as fish behavior characteristic parameters; and establishing a correlation model between the pulse electric field parameters and the fish behavior characteristic parameters, and quantitatively analyzing the influence of the electric field parameters on the fish behaviors. According to the method provided by the invention, the correlation model of the characteristic behaviors and the electric field parameters is established by acquiring and analyzing the whole-process characteristic behavior data of the fishes in the electric field, so that the electric field parameter setting of the fish blocking electric grid can be effectively evaluated and optimized.

Owner:CHANGJIANG RIVER SCI RES INST CHANGJIANG WATER RESOURCES COMMISSION