

Patents
Literature
36results about How to "Positioning data is accurate" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Bridge inspection method
InactiveCN109901624AHigh degree of automationImprove stabilityOptically investigating flaws/contaminationPosition/course control in three dimensionsUncrewed vehicleWorkload
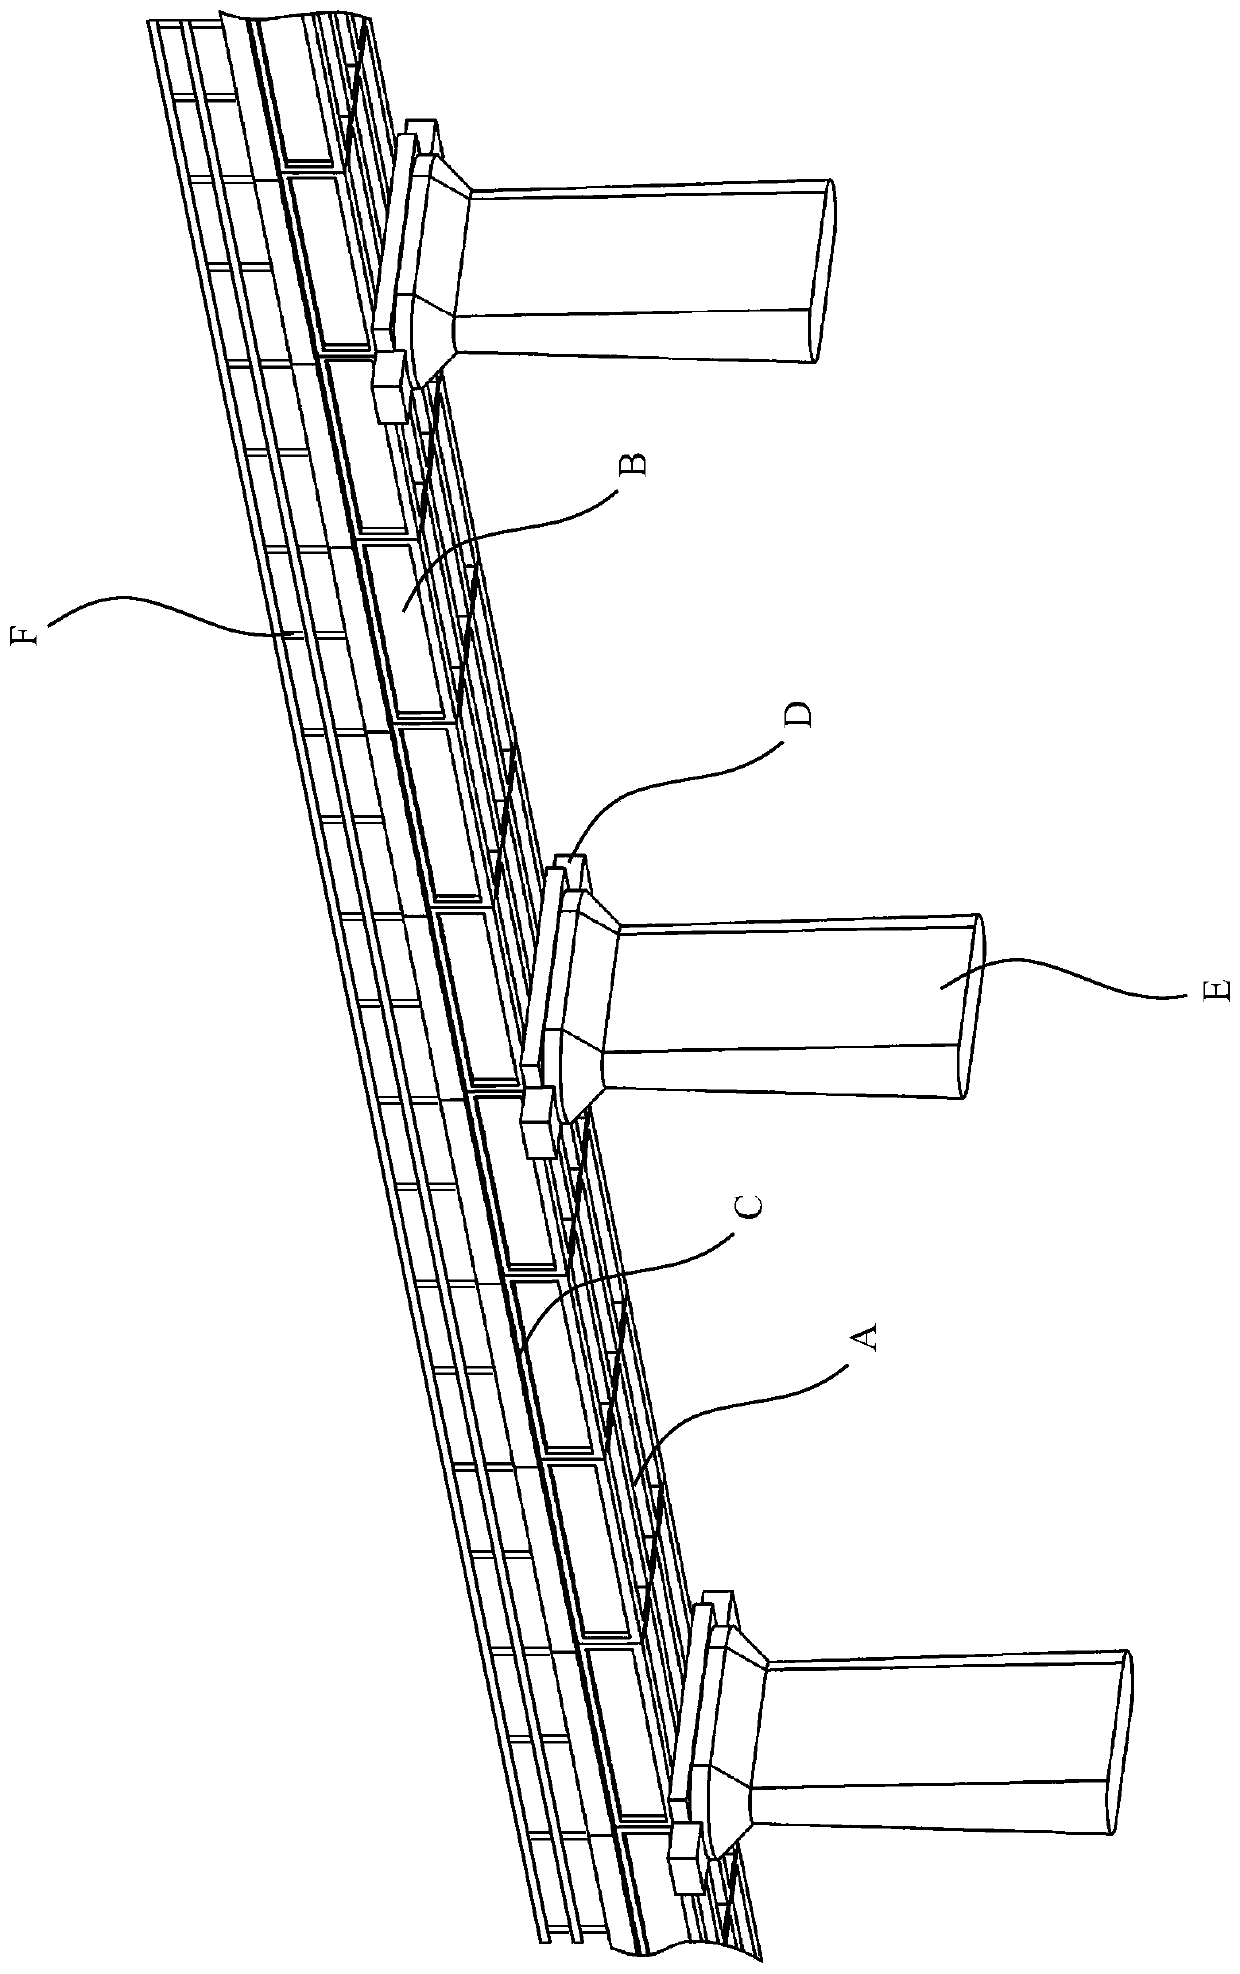
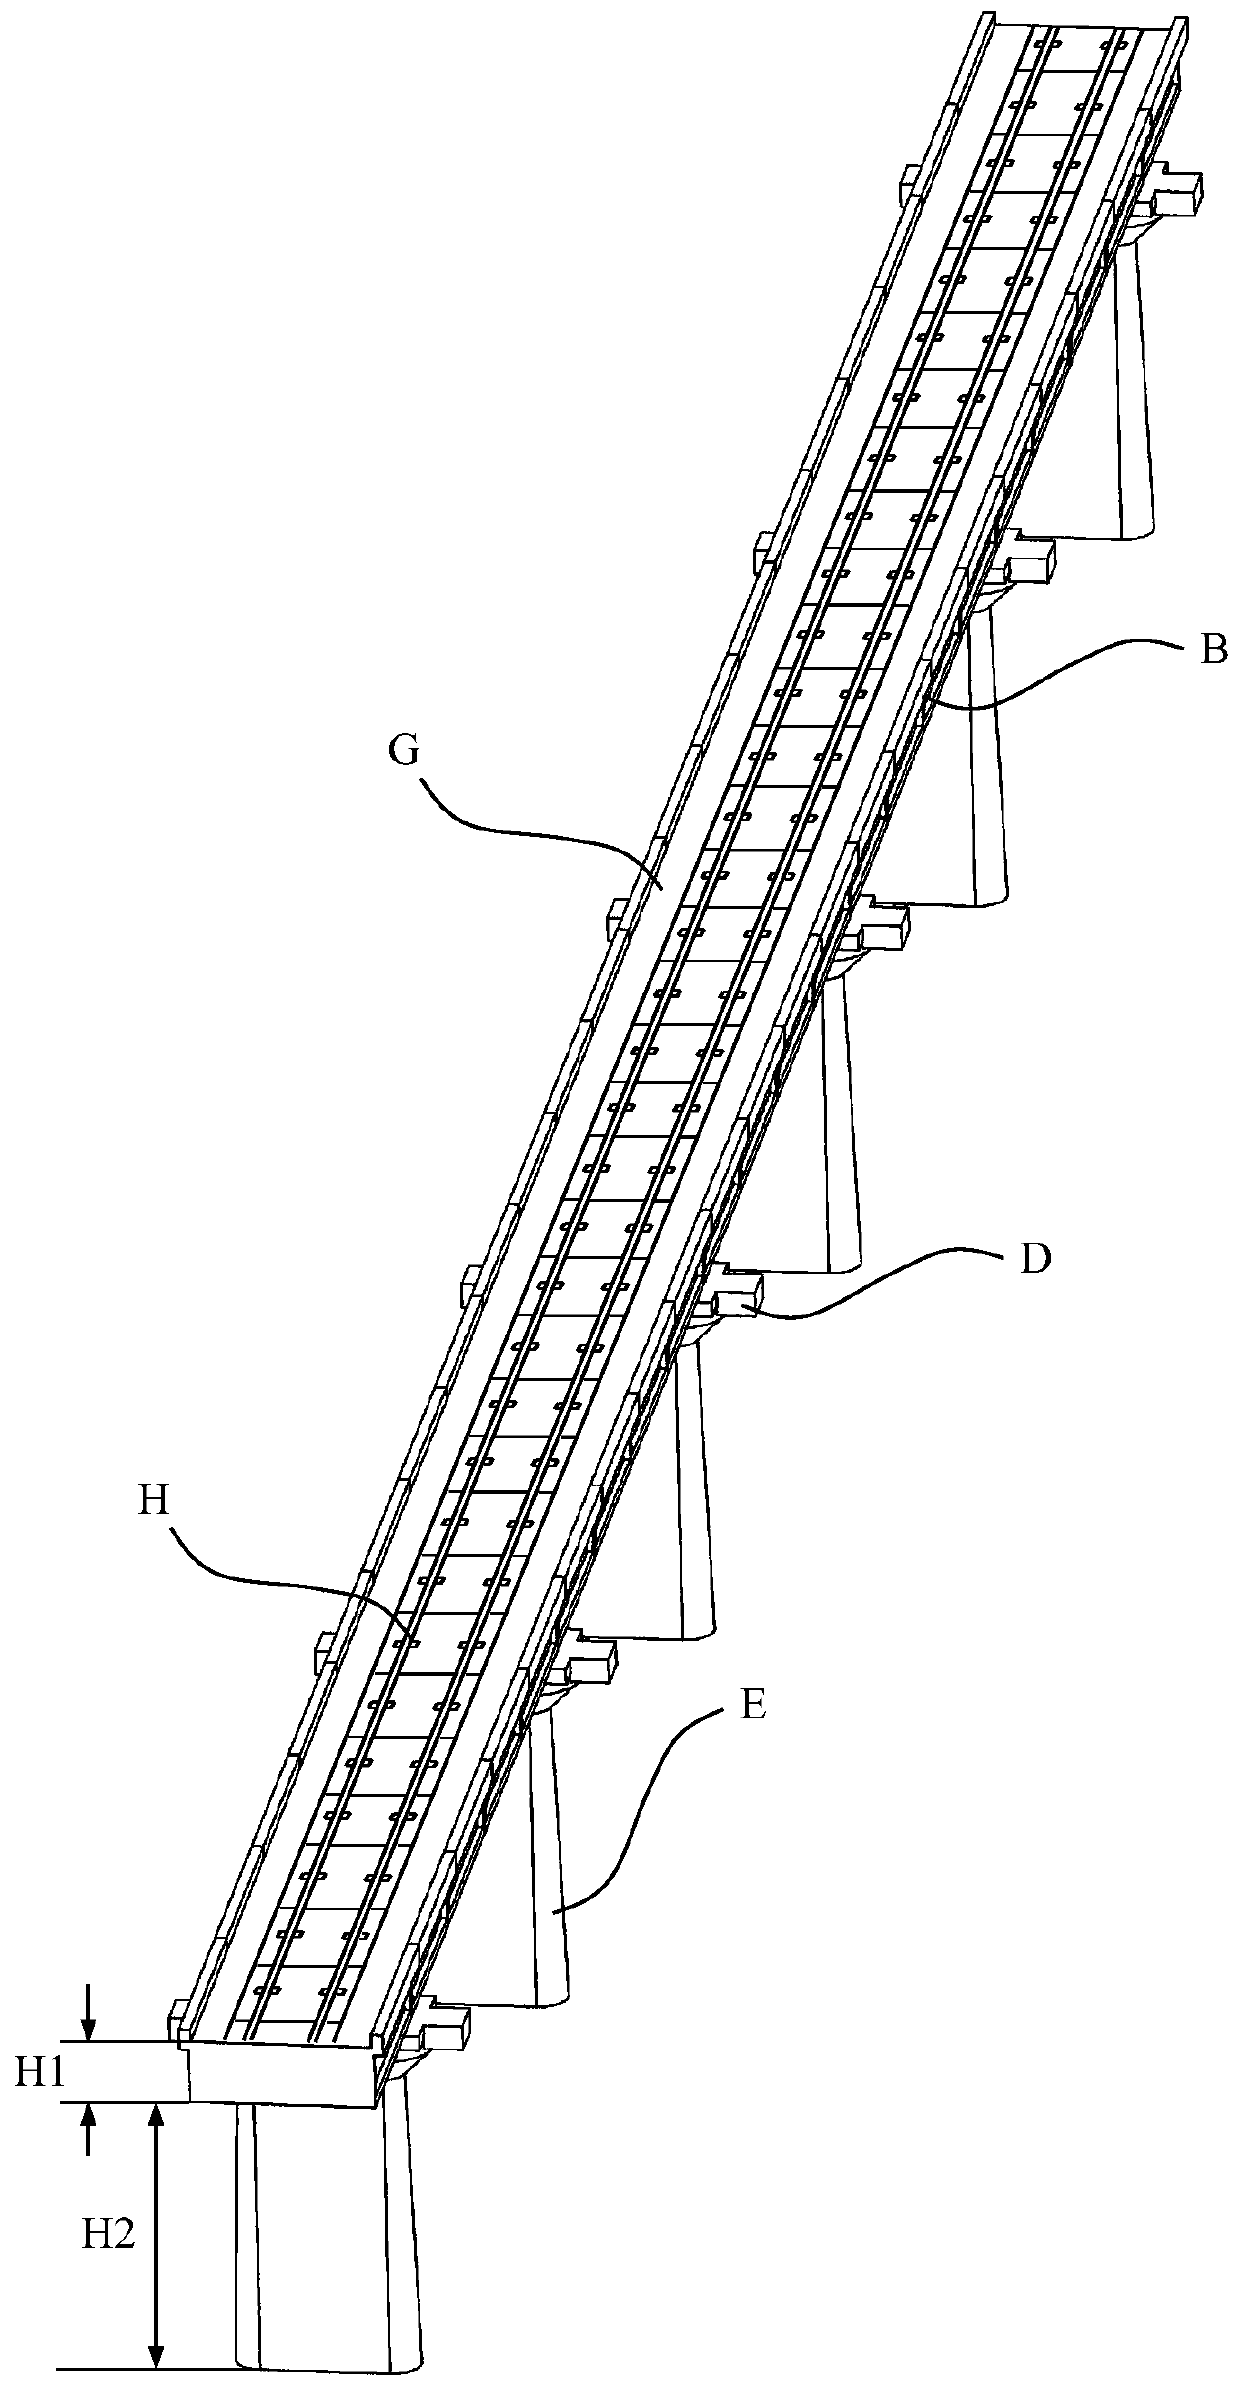
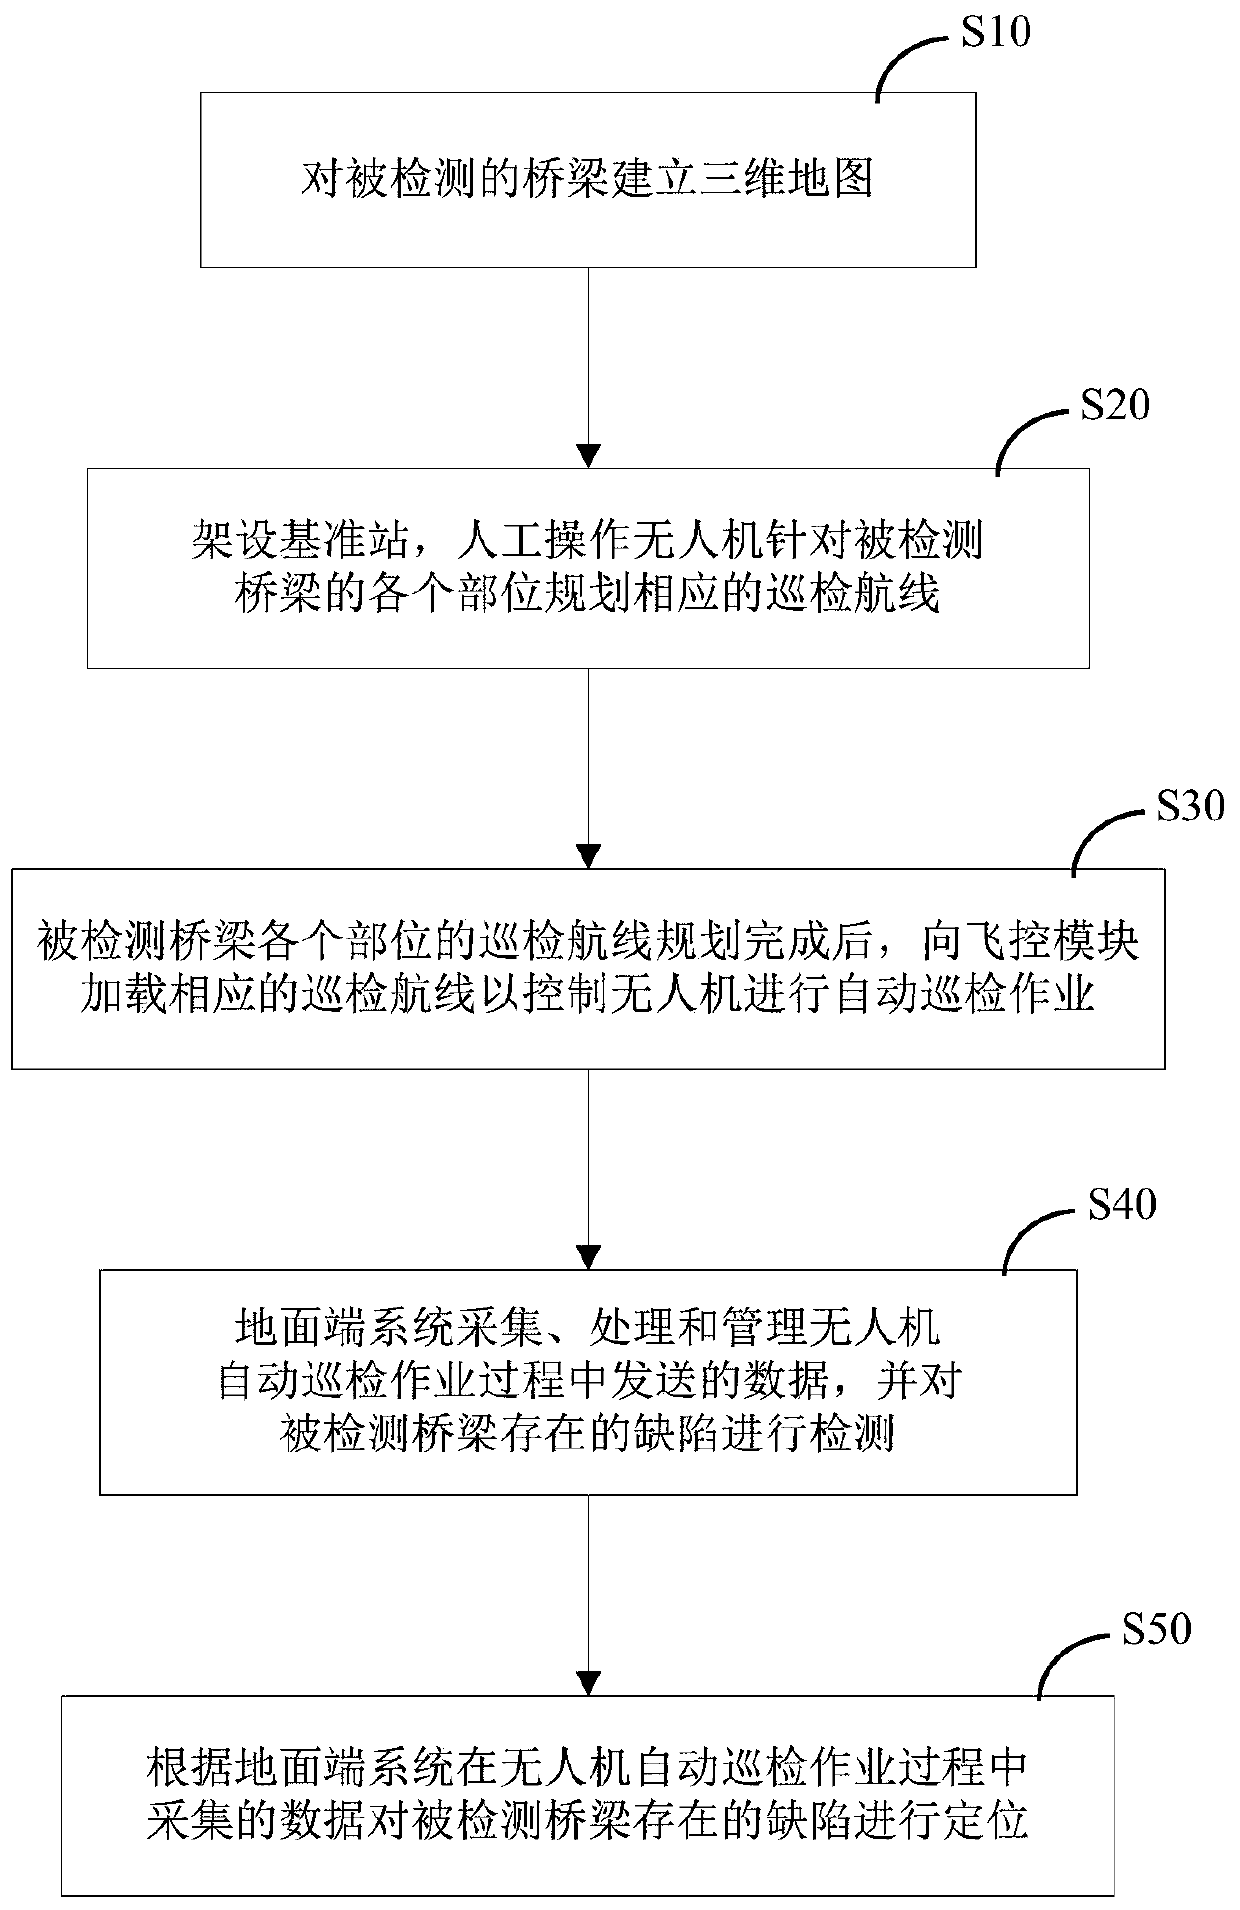
The invention discloses a bridge inspection method comprising the following steps: S10, establishing a three-dimensional map of a detected bridge; S20, erecting a base station and controlling an unmanned aerial vehicle manually to plan corresponding inspection routes for all parts of the detected bridge; S30, after completion of inspection route planning of all parts of the detected bridge, loading a corresponding inspection route for a flight control module to control the unmanned aerial vehicle to carry out automatic inspection; S40, collecting, processing, and managing data sent by the unmanned aerial vehicle in an automatic inspection working process by a ground station and detecting defects existing in the detected bridge; and S50, locating the defects existing in the detected bridgeaccording to the data received by the ground station in the automatic inspection working process of the unmanned aerial vehicle. Therefore, technical problems that the automation degree is low, the workload is large, the stability of the acquired data is poor, and the safety is low because the existing UAV bridge inspection mode mainly relies on the manual operation for bridge surface data collection by the UAV are solved.
Owner:ZHUZHOU TIMES ELECTRONICS TECH CO LTD
Bridge inspection system
ActiveCN109901625AHigh degree of automationImprove stabilityNavigational calculation instrumentsOptically investigating flaws/contaminationEngineeringGround station
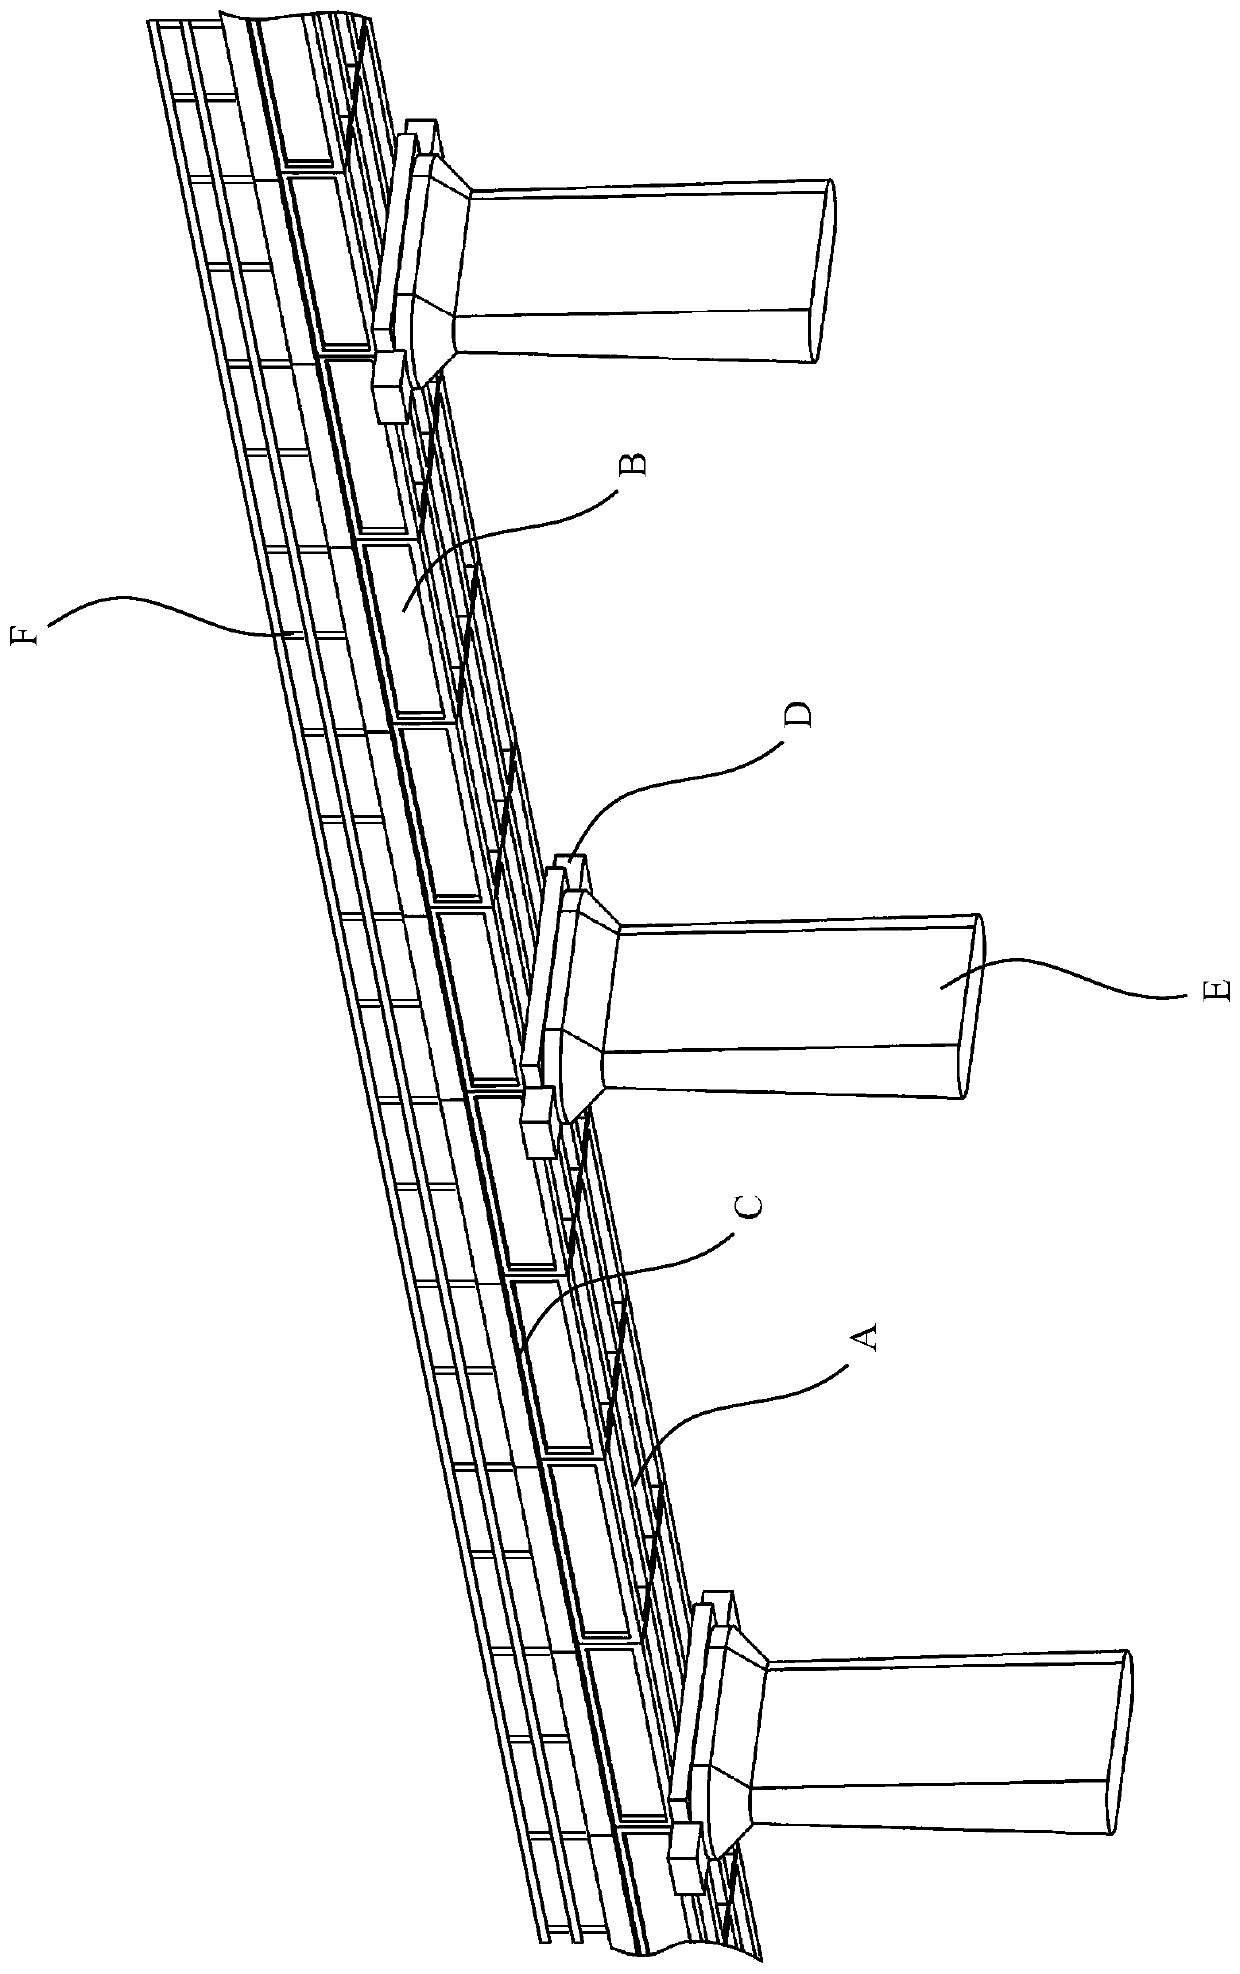
The invention discloses a bridge inspection system. An unmanned aerial vehicle carries out first inspection on a bridge needing detection under the manual operation; a cloud desk camera carried out bridge surface data collection and generates an inspection route based on a positioning signal obtained by a positioning module; an unmanned aerial vehicle carries out inspection automatically based onan inspection route of a writing flight control module; an airborne data processing unit carries out processing based on data sent by an obstacle avoidance module; and the flight control module controls the unmanned aerial vehicle to carry out automatic obstacle avoidance emergency treatment. The cloud desk camera carries out video acquisition and image capturing according to set parameters in theautomatic inspection process; videos collected by the cloud desk camera are sent to a ground terminal system for display; and a ground station performs defect detection and positioning according to the captured images during the automatic inspection process. According to the invention, technical problems that the automation degree is low, the workload is large, the stability of the acquired datais poor, and the safety is low because the existing UAV bridge inspection mode mainly relies on the manual operation for bridge surface data collection by the UAV are solved.
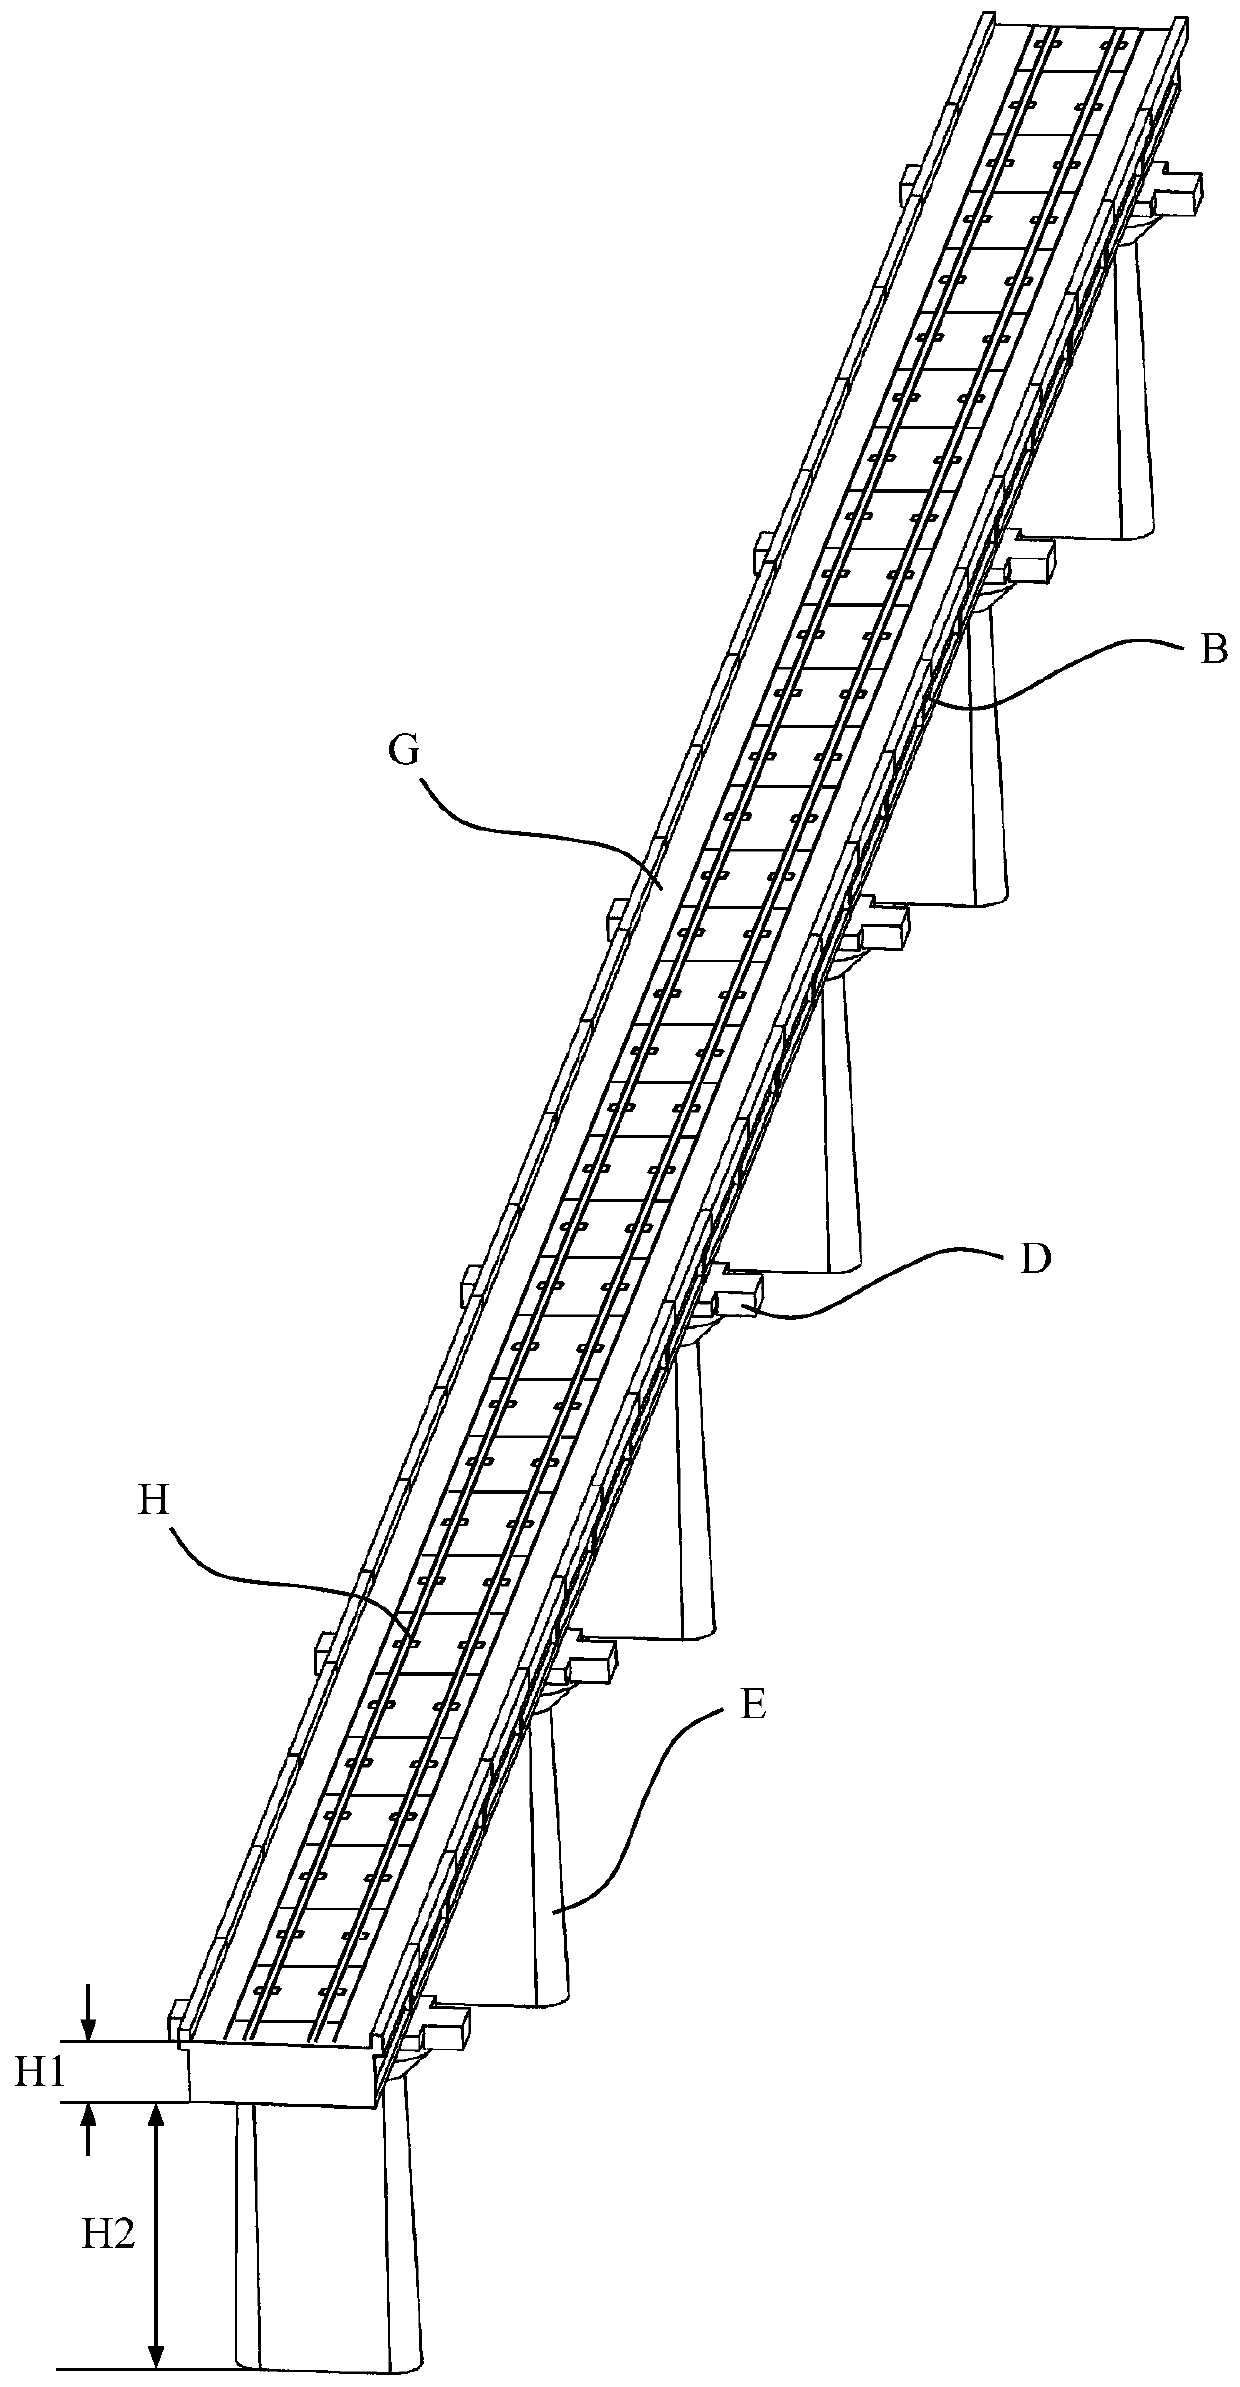
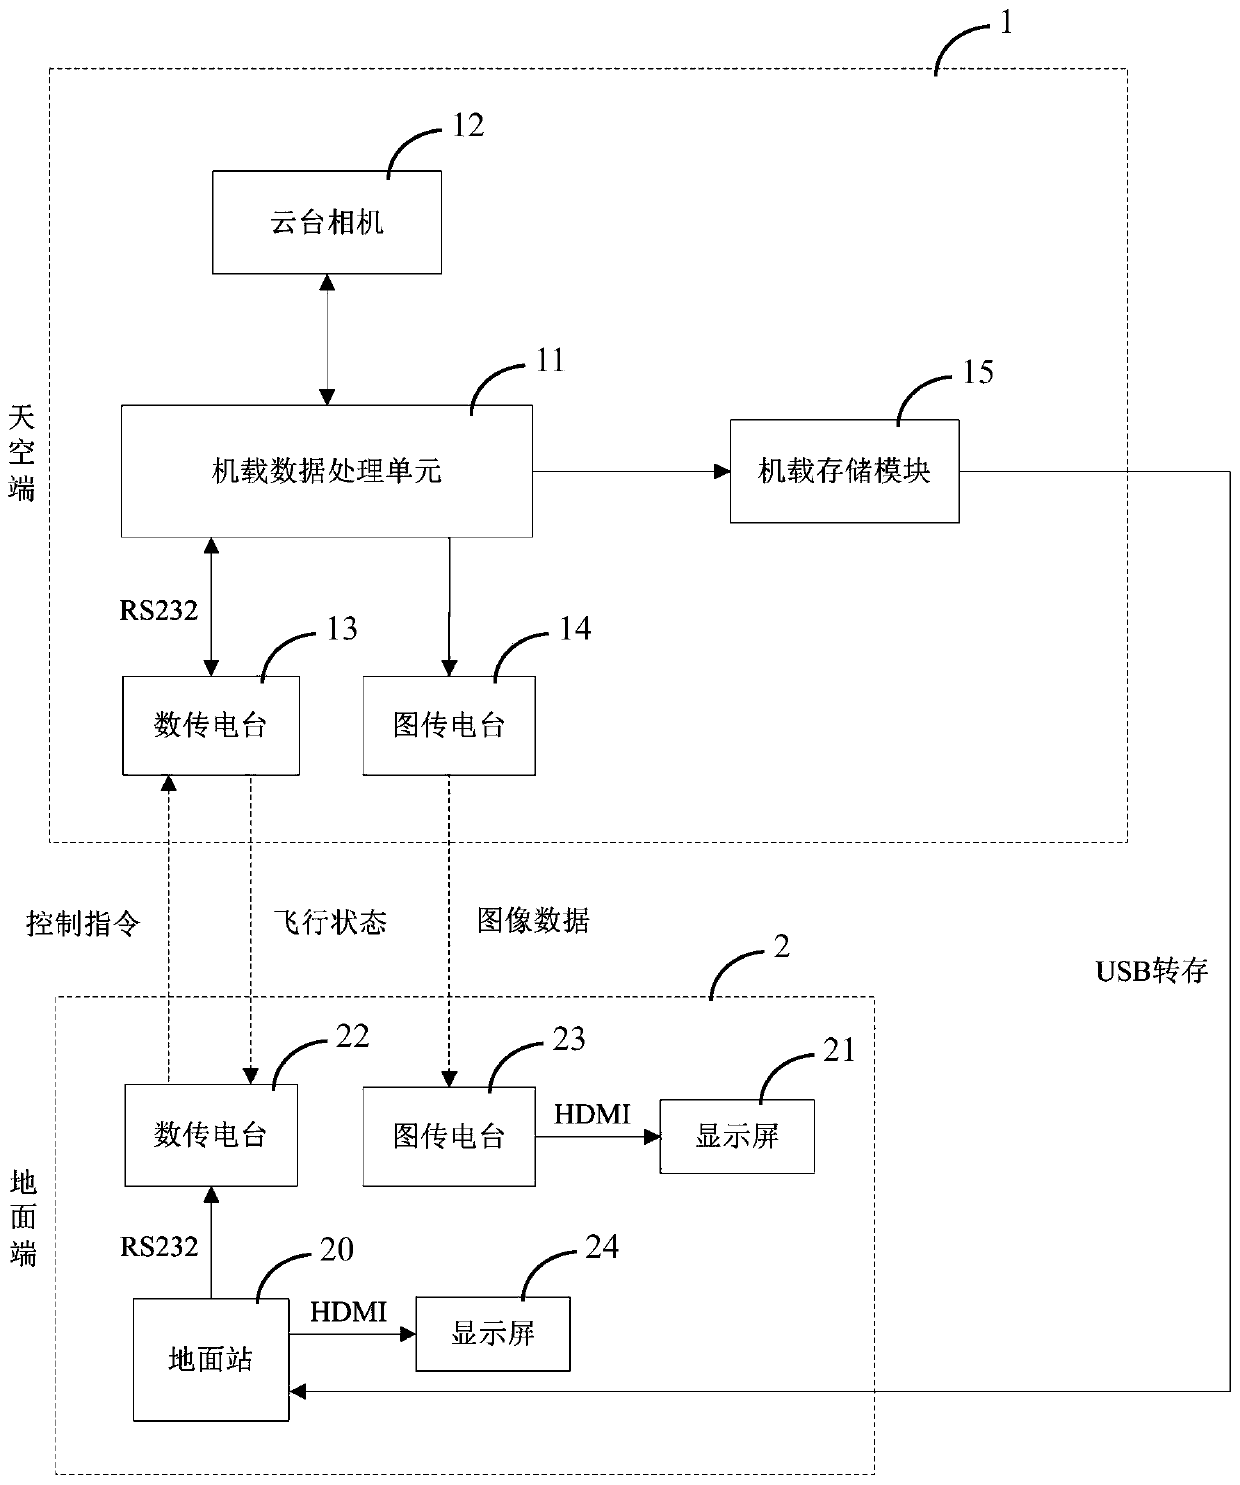
Owner:ZHUZHOU TIMES ELECTRONICS TECH CO LTD
Ground transport vehicle control device and control method thereof
PendingCN107861511AReduce the numberLow costPosition/course control in two dimensionsIn vehicleControl system
The invention discloses a ground transport vehicle control device and a control method thereof. An upper and lower integrated control system is formed by an upper computer and an AGV system. Optimal task allocation and cooperative allocation of a plurality of AGVs forming the AGV system can be obtained through an upper computer running program, and butt joint can be accomplished through a plurality of ultrasonic receiving systems in an ultrasonic automatic following, receiving and positioning system to completely cover the whole control area, so that errors caused by wave losing and restrictions of a blind area can be avoided, the positioning range of each ultrasonic receiving system is enabled to be wider, the number of the ultrasonic receiving systems is reduced, the cost is reduced, thepositioning data is more accurate, and the reliability is high; a vehicle-mounted display screen can display the located position, the speed and local obstacle information in real time; meanwhile, anobstacle avoidance system is adopted, static and dynamic obstacles within different ranges can be avoided in a fast response and accurate distance manner, and the fault tolerance rate is improved; and the overall system is stable in performance, a problem that the traditional ultrasonic positioning system is too large in blind area is solved, and the operation cost and the maintenance cost are low.
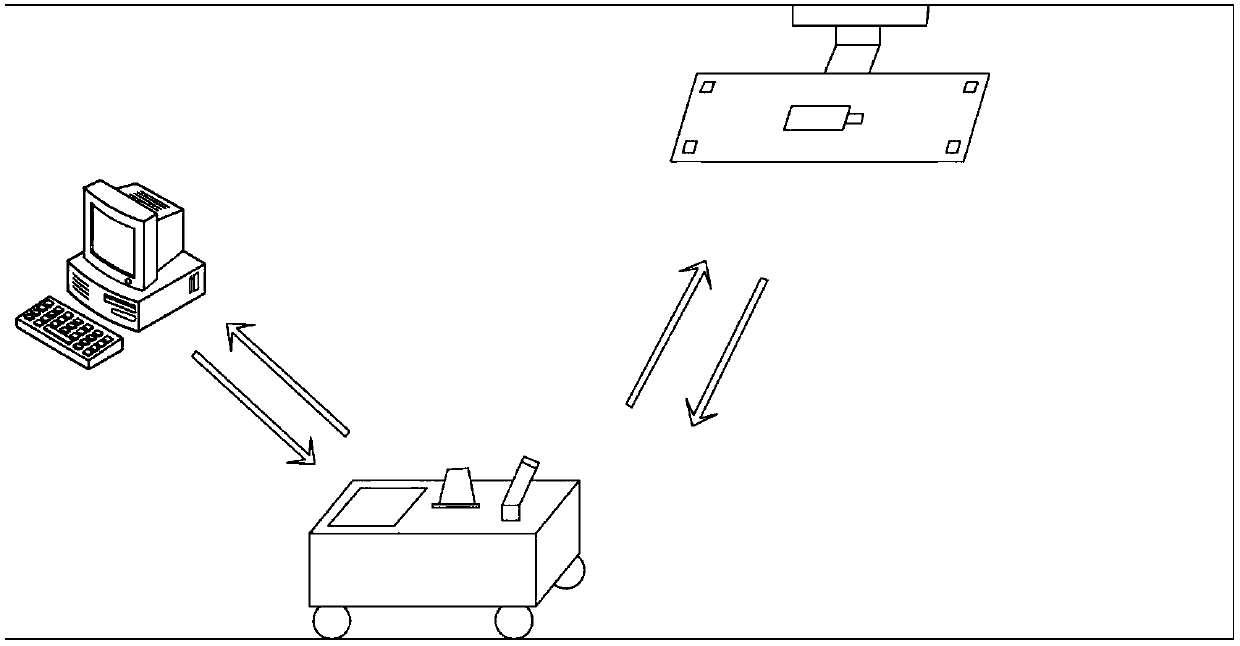
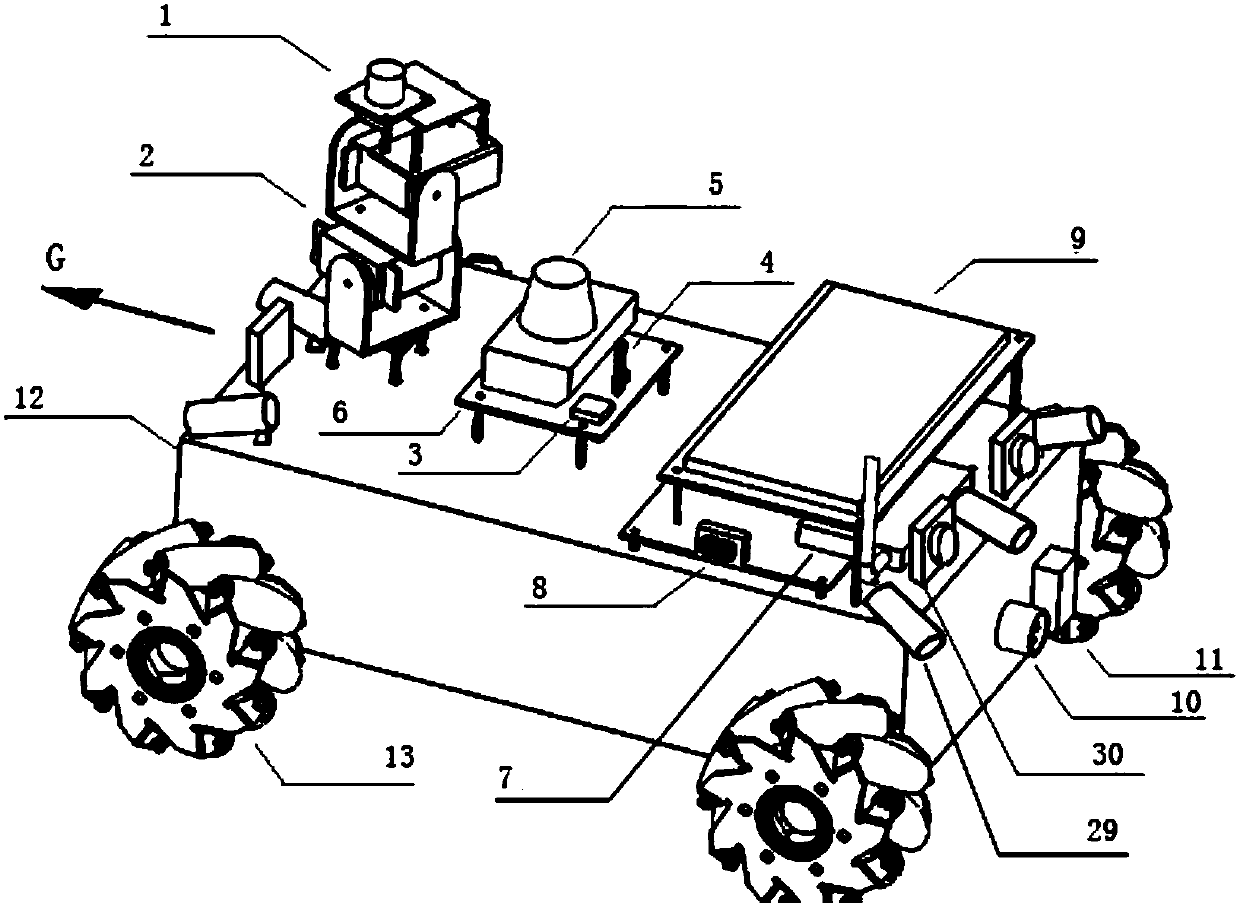
Owner:HEBEI UNIVERSITY OF SCIENCE AND TECHNOLOGY
Aircraft autonomous navigation method and system and aircraft
PendingCN111142559AContinuous positioning dataPositioning data is accuratePosition/course control in three dimensionsUltra-widebandFlight vehicle
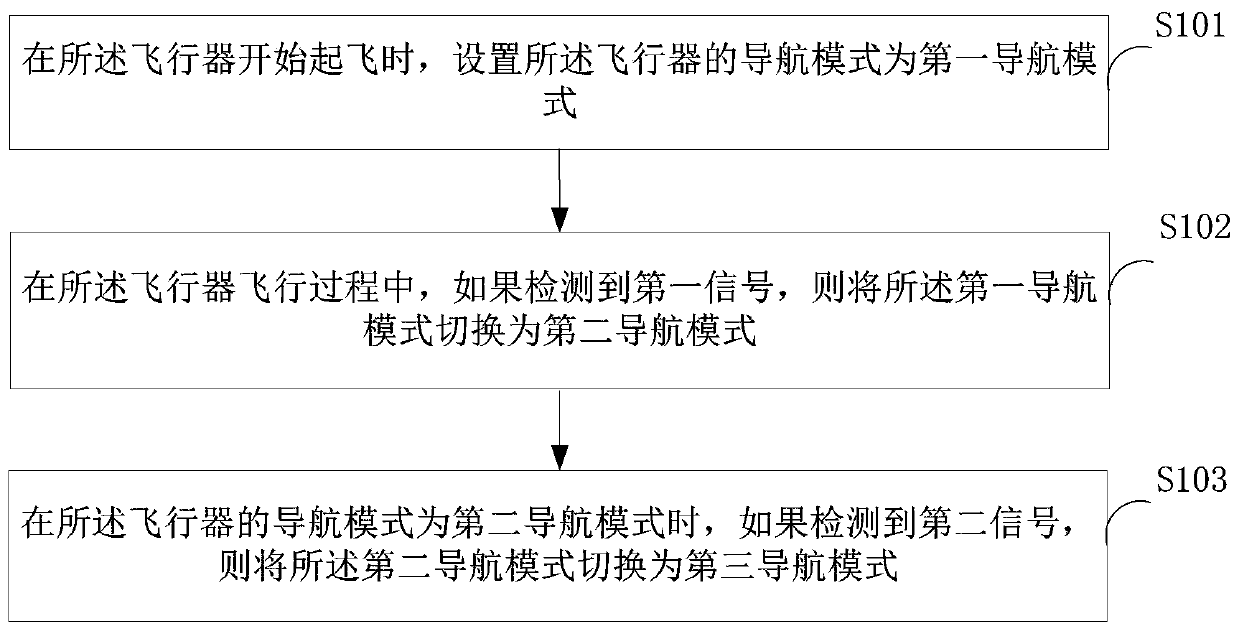
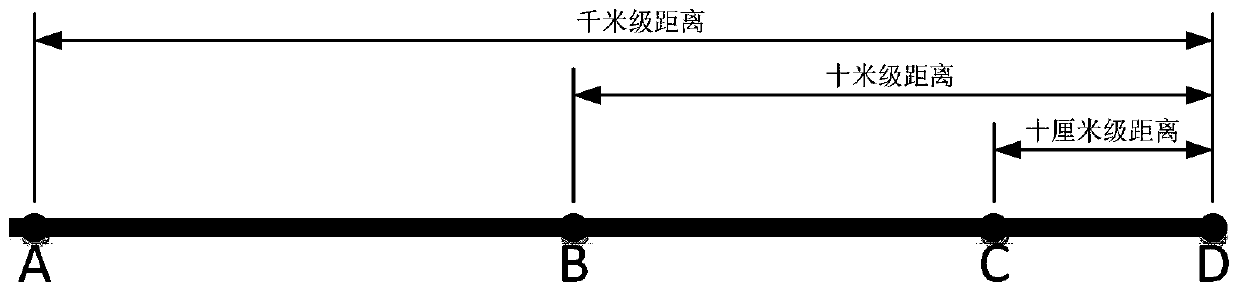
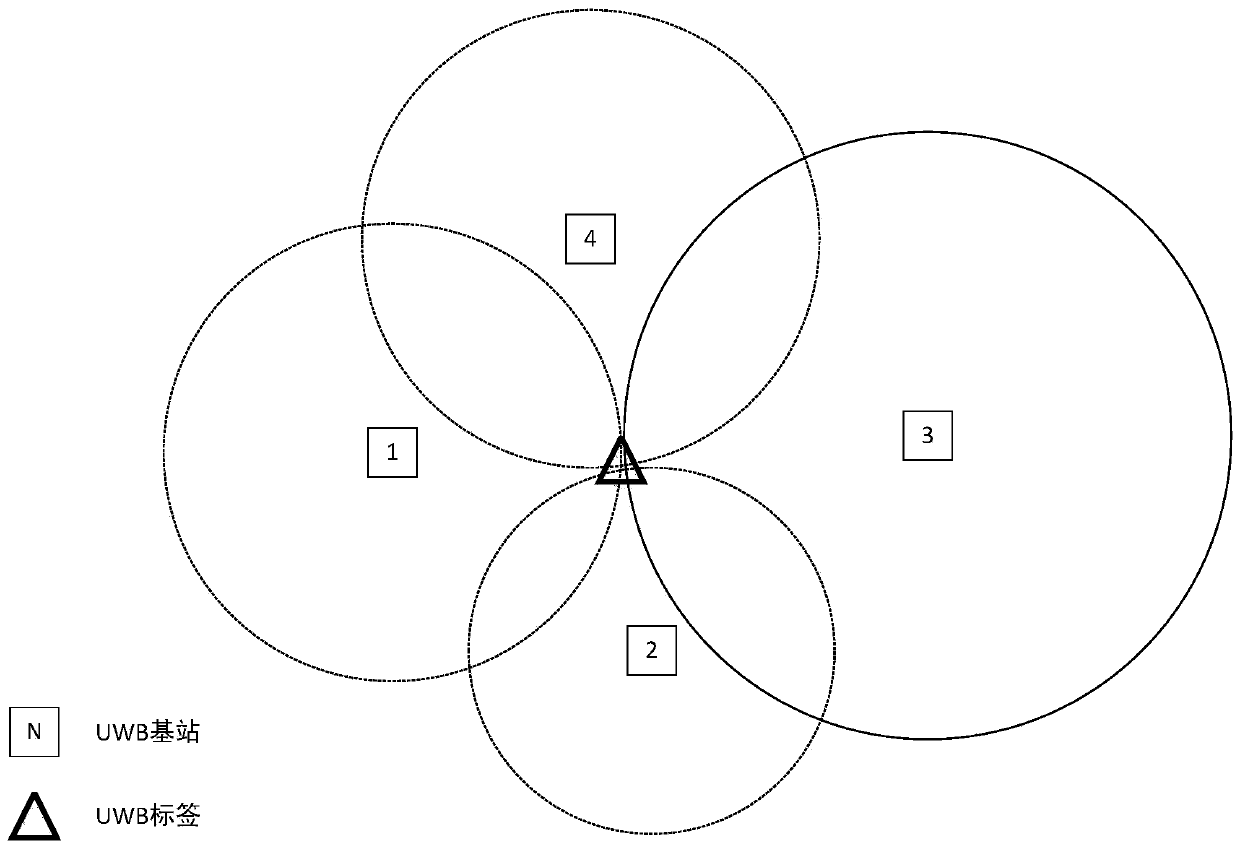
The invention belongs to the field of unmanned aerial vehicles and provides an aircraft autonomous navigation method and system and an aircraft. The method includes the following steps that: when an aircraft starts to take off, the navigation mode of the aircraft is set to be a first navigation mode; during the flight of the aircraft, if it is detected a signal generated when the ultra-wideband (UWB) positioning sensor of the aircraft establishes connection with the UWB base station of the target landing point of the aircraft is detected, the first navigation mode of the aircraft is switched to a second navigation mode; when the navigation mode of the aircraft is the second navigation mode, if a preset pattern is detected, the second navigation mode of the aircraft is switched into a thirdnavigation mode. The three different navigation modes are provided for providing continuous and accurate positioning data for the aircraft, so that the autonomous navigation of the aircraft is realized, and therefore, a user does not need to depend on a remote controller to control flight navigation and make the aircraft land to a target landing point, and therefore, user experience is improved.
Owner:UBTECH ROBOTICS CORP LTD
Mobile robot positioning method and system based on instance segmentation and multi-sensor fusion, and medium
ActiveCN112734765AHigh precisionNot prone to positioning failuresImage enhancementImage analysisPattern recognitionCamera image
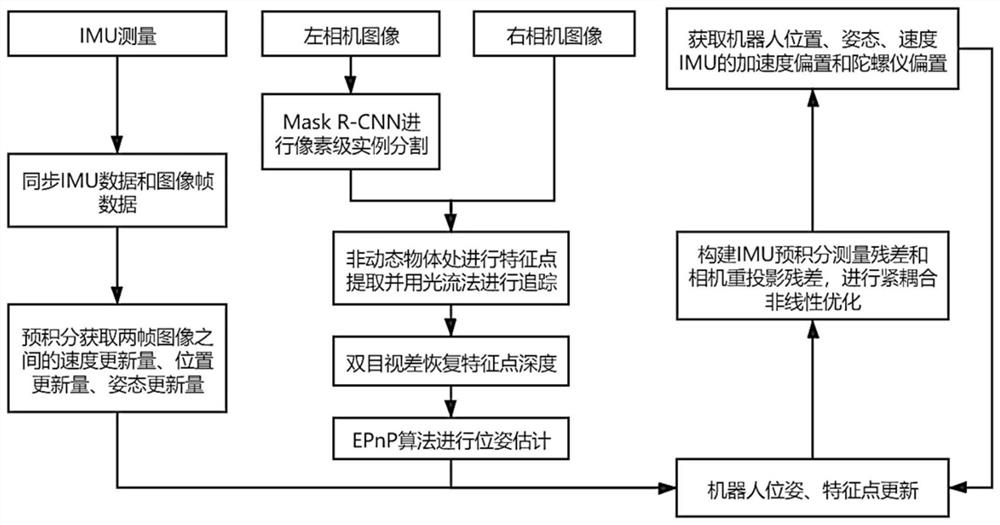
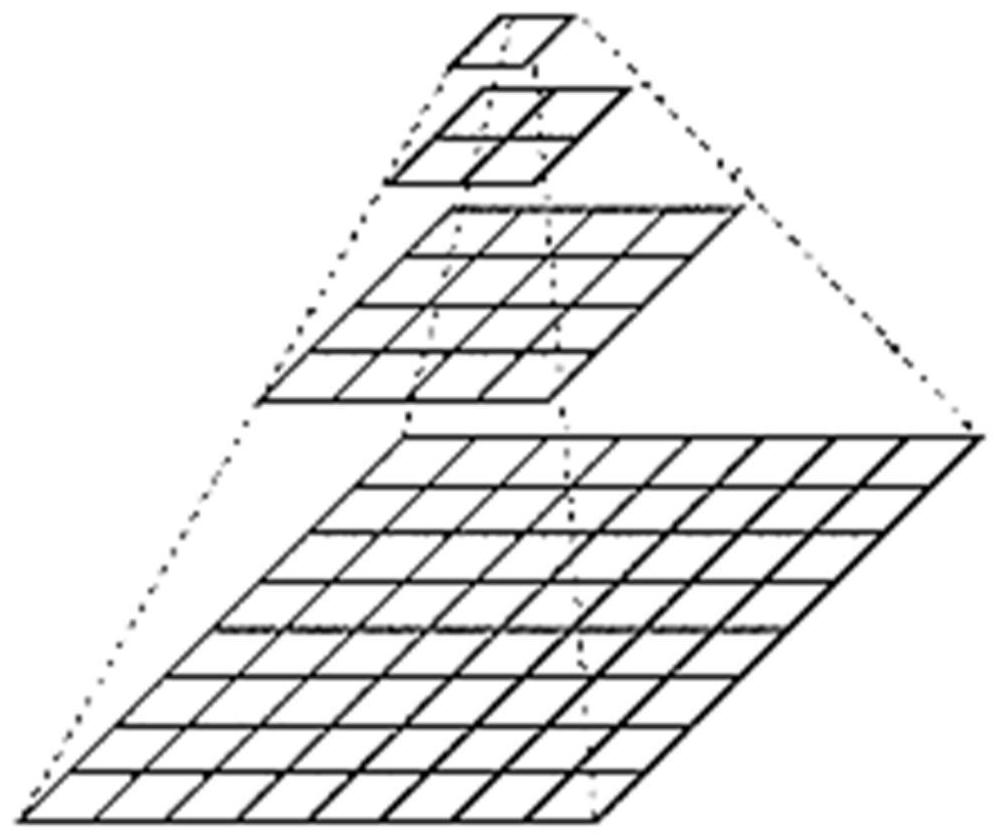
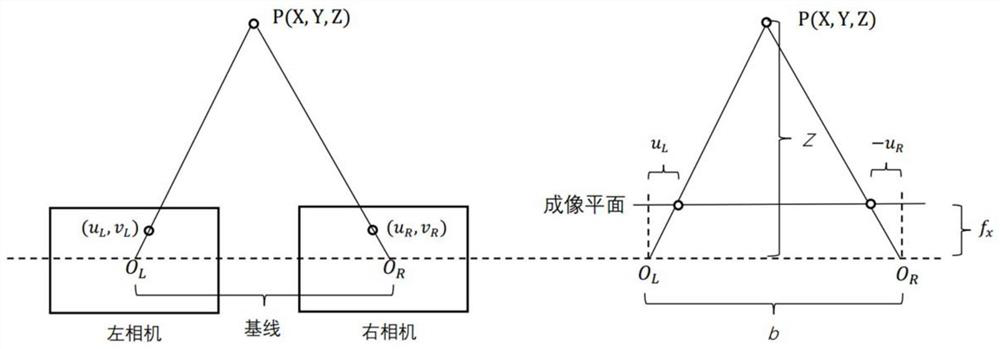
The invention discloses a mobile robot positioning method and system based on instance segmentation and multi-sensor fusion, and a medium. The method comprises the following steps: carrying out target instance segmentation on a camera image; extracting and tracking feature points of the segmented image; calculating a depth value of the feature point and carrying out pose calculation by using an EPnP algorithm; carrying out pose calculation based on IMU pre-integration; selecting an updating mode of the pose initial value according to the instance segmentation information and the feature point extraction condition; and enabling the visual sensor and the IMU to be subjected to tight coupling pose optimization, and obtaining an accurate pose. According to the method, the instance segmentation information of the image is acquired, the static feature points in the complex environment are selected as the reference, the pose state of the robot is estimated, and the IMU can be switched to update the positioning initial value information when the camera positioning is not ideal, so that the positioning of the robot also has accuracy and robustness in a highly dynamic environment.
Owner:SOUTH CHINA UNIV OF TECH
Dangerous goods transportation safety detection method and system thereof
InactiveCN108389199AEfficient identificationReduce lossesImage enhancementData processing applicationsVideo monitoringHazardous materials transportation
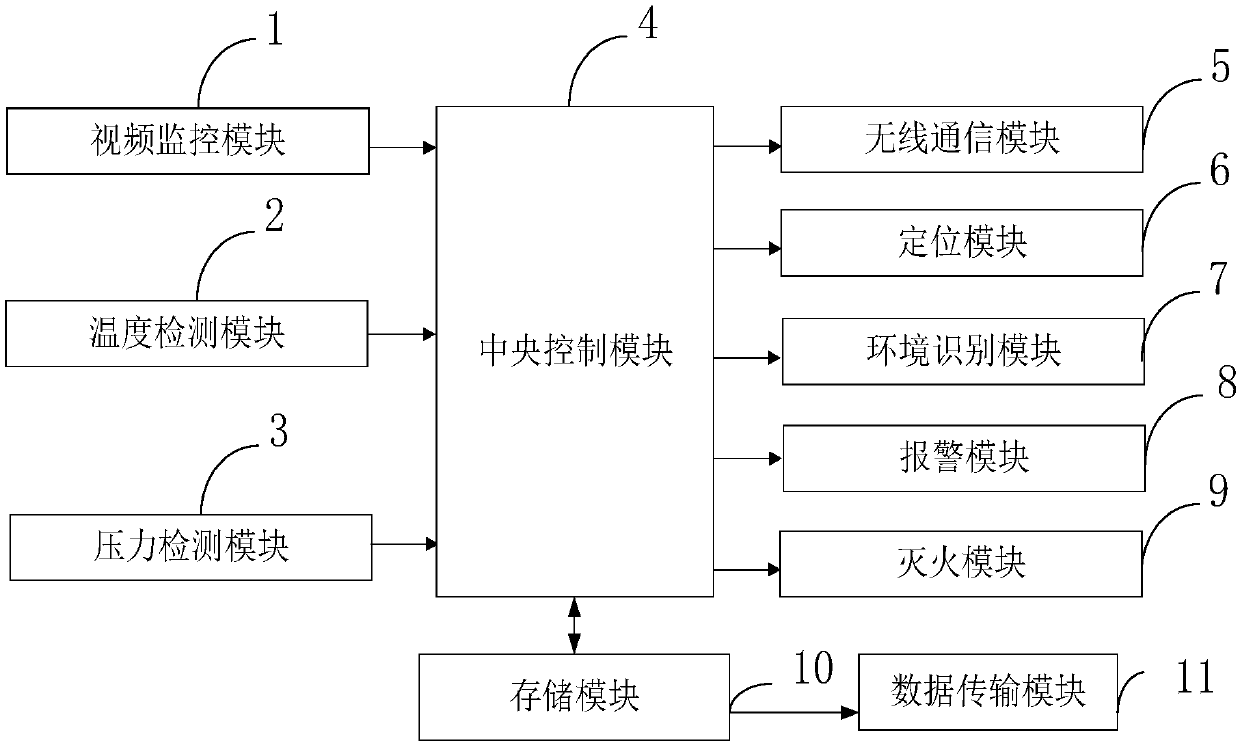
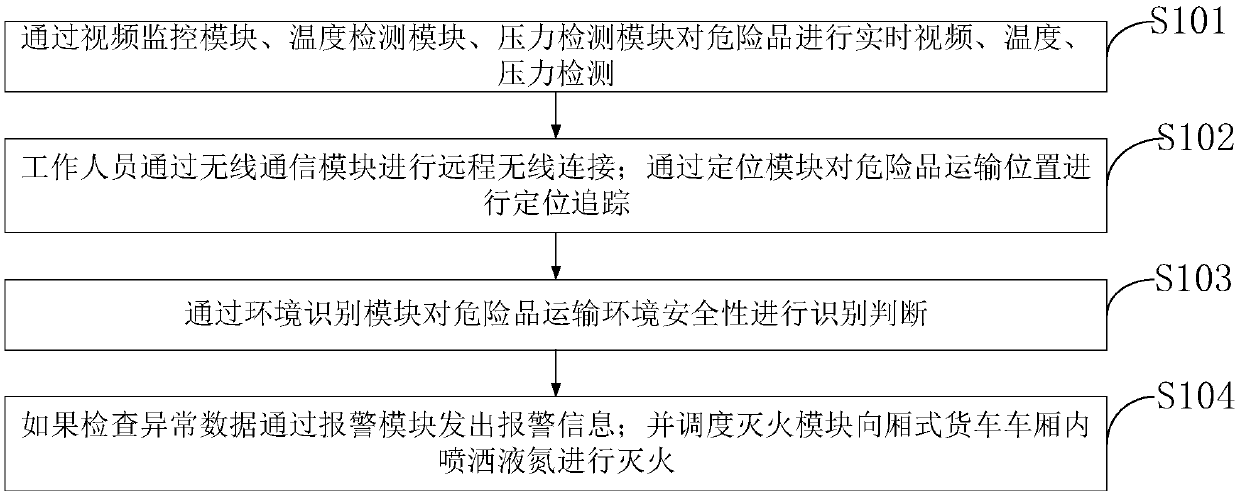
The invention belongs to the technical field of dangerous goods transportation safety detection and discloses a dangerous goods transportation safety detection method and a system thereof. The systemcomprises a video monitoring module, a temperature detection module, a pressure detection module, a central control module, a wireless communication module, a positioning module, an environment identification module, an alarm module, a fire extinguishing module and a storage module. On the basis of detecting the shape of the dangerous goods itself and surrounding environment requirements by the environment identification module, surrounding environment factors which affect the safety of the dangerous goods are detected; then, according to the shape of the dangerous goods itself and the surrounding environment requirements and the surrounding environment factors which affect the safety of the dangerous goods, the safety level of the dangerous goods surrounding environment is compared and judged, the surrounding environment in the case of dangerous goods transportation is recognized, the environment surrounding the dangerous goods can be effectively identified, and guarantee is providedfor safety transportation of the dangerous goods; and through the alarm module and the fire extinguishing module, quick fire extinguishing can be carried out, and accident losses are reduced.
Owner:GUANGDONG UNIV OF PETROCHEMICAL TECH
Method and device for processing projection calibration information on basis of information feedback
InactiveCN102681303ARelaxation of rectification conditionsLow costTelevision system detailsProjectorsComputer graphics (images)Projection screen
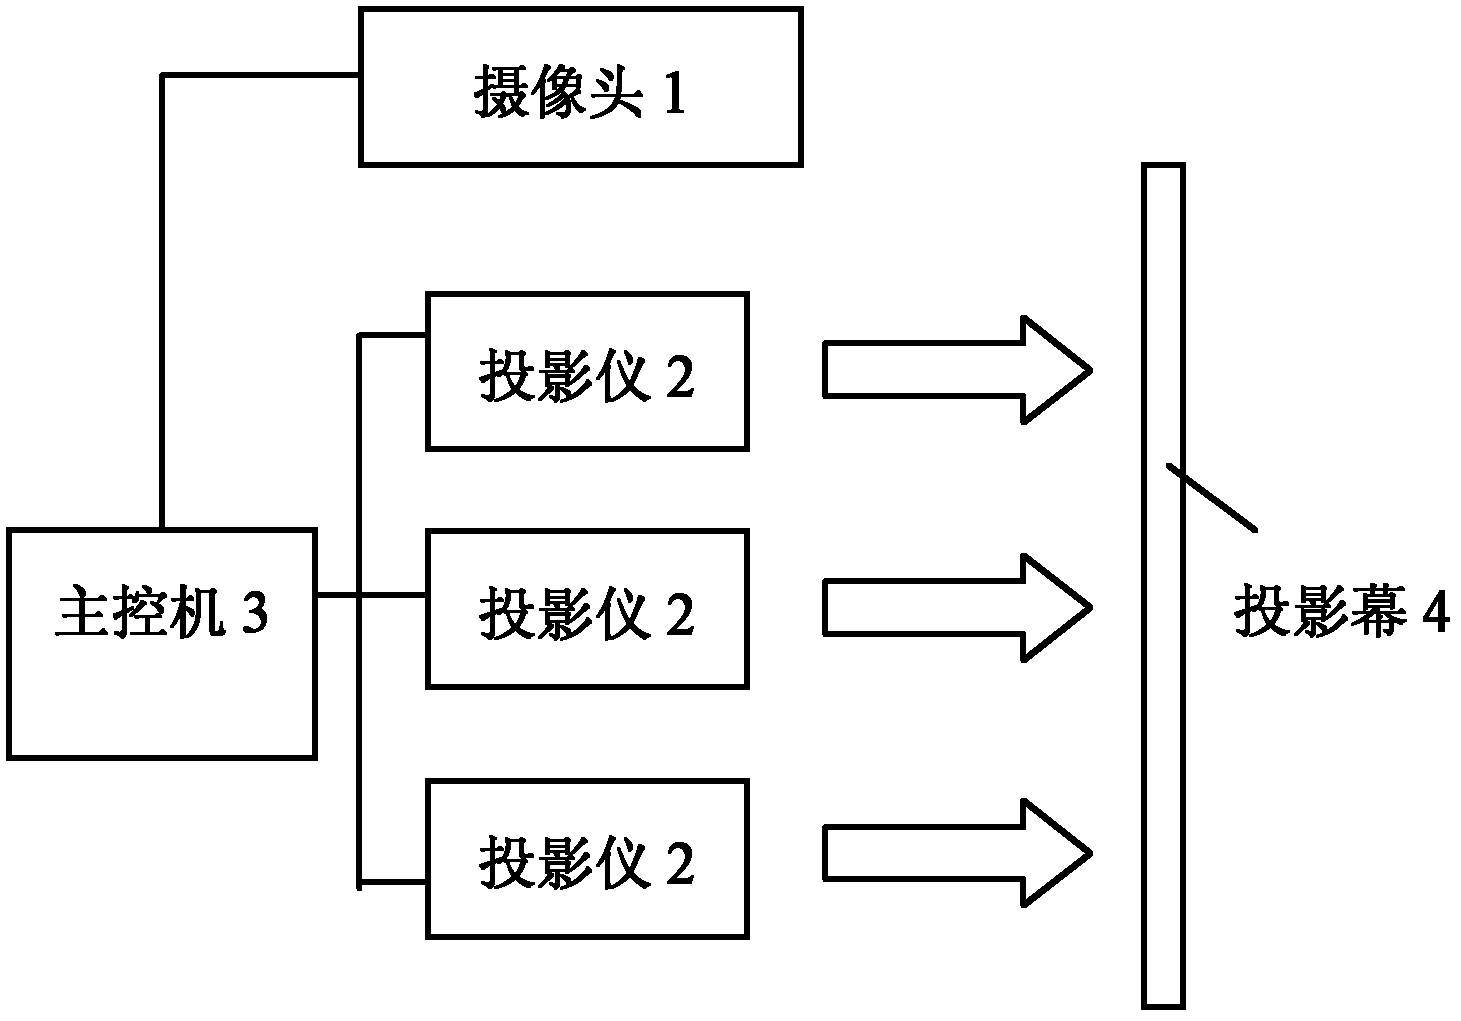
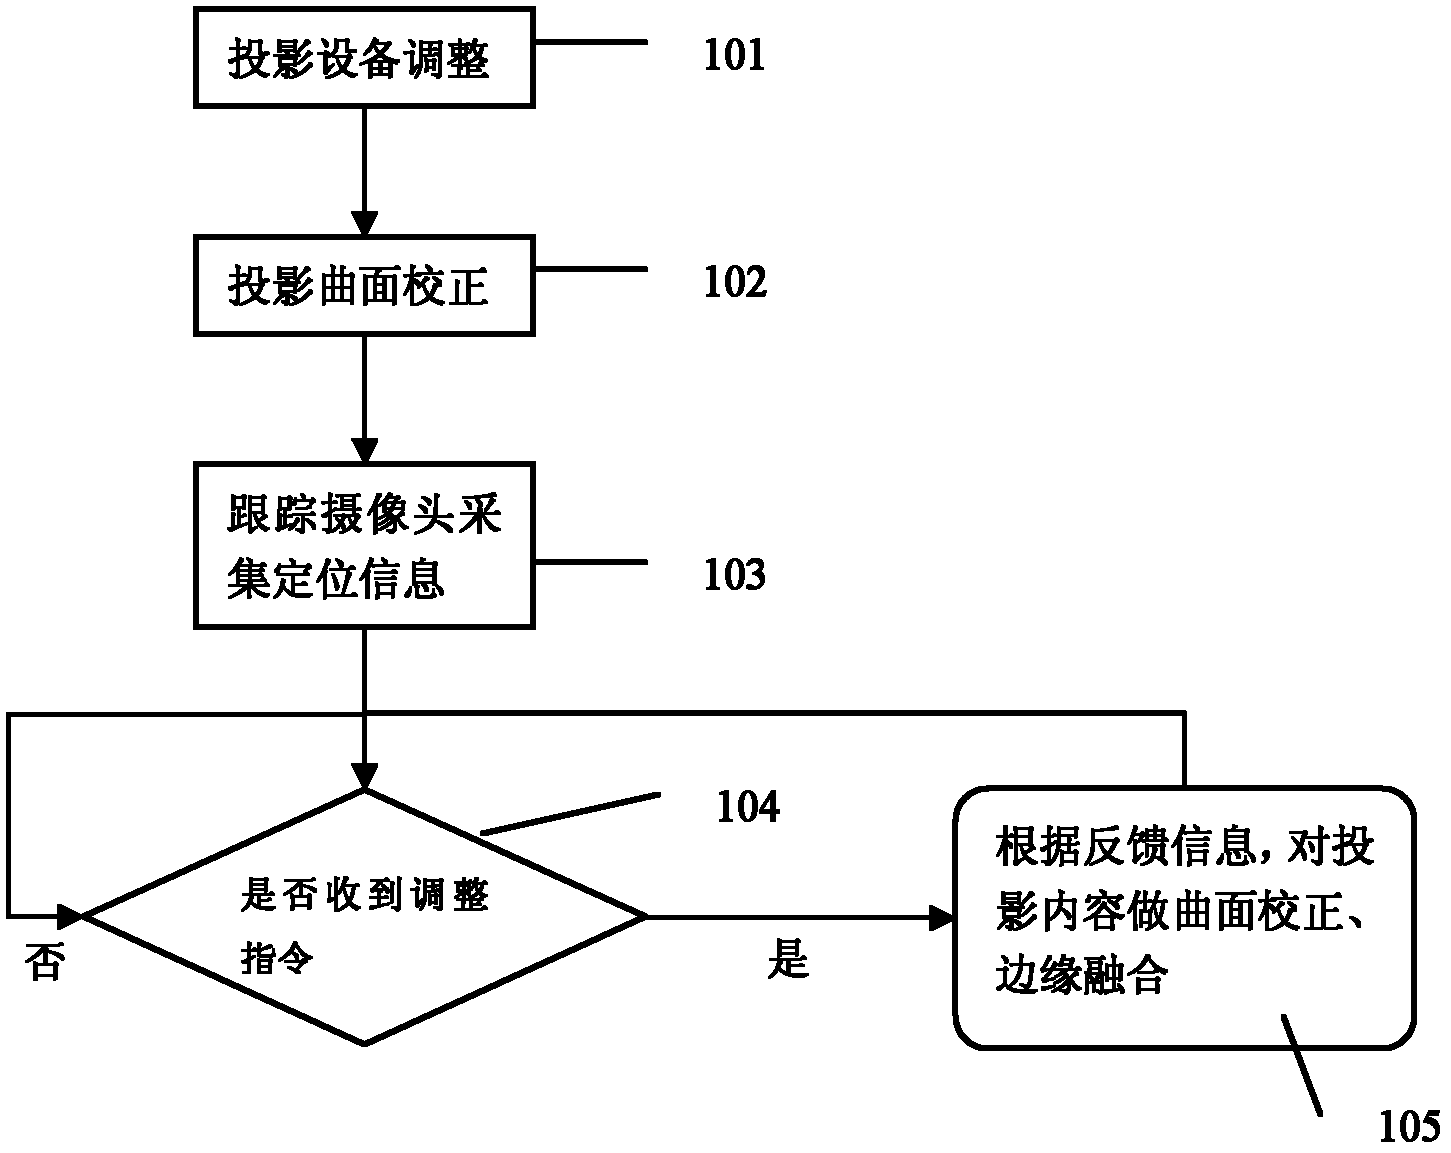
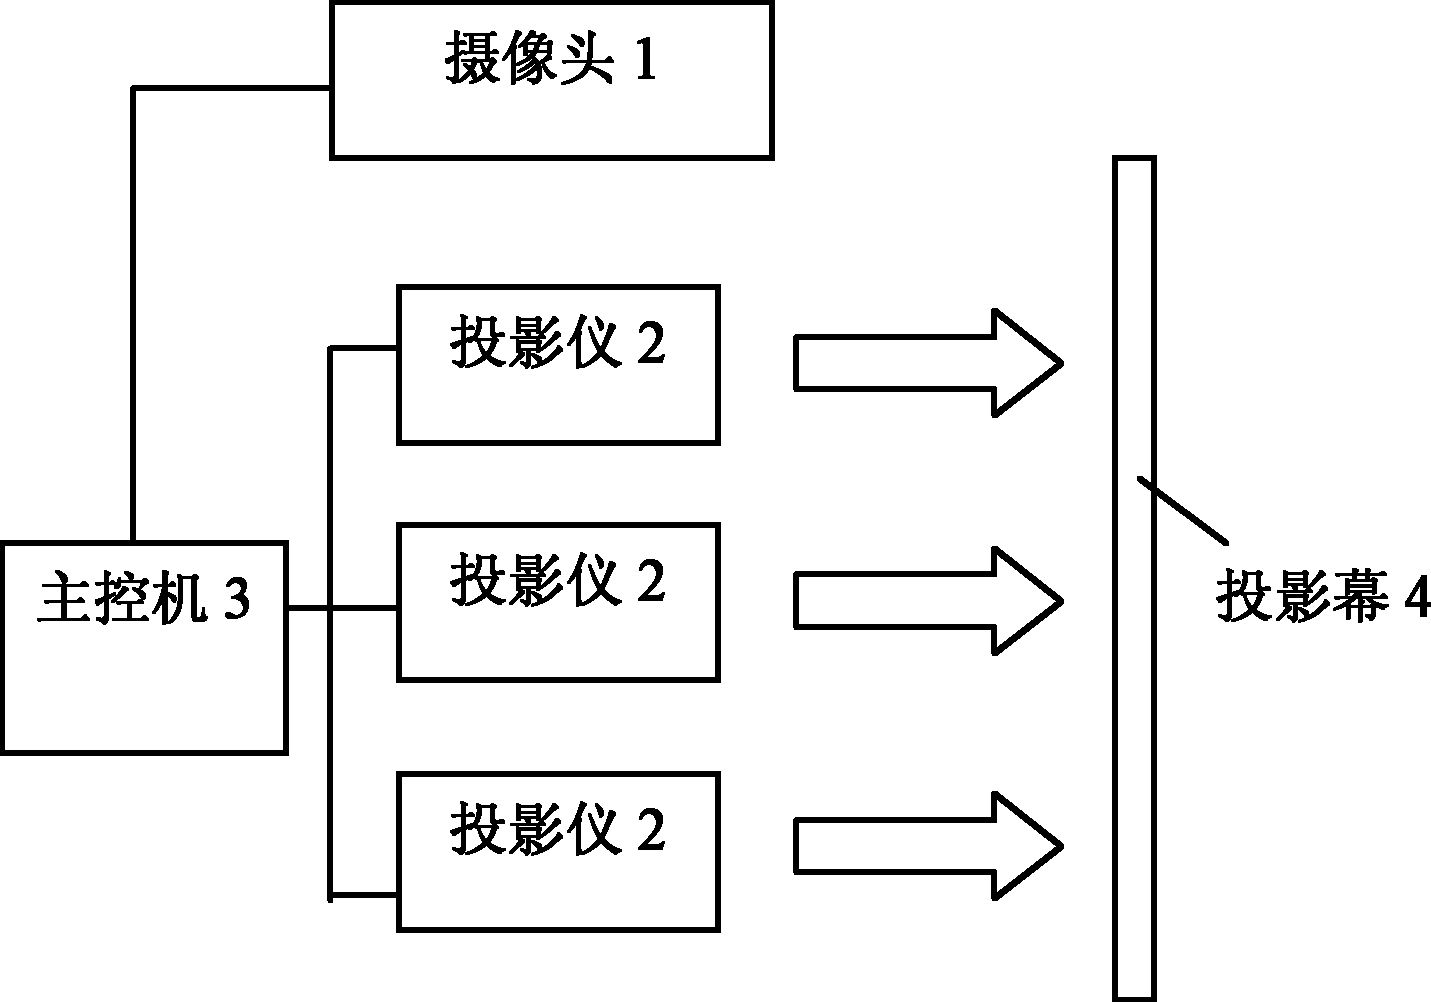
The invention relates to a method and a device for processing projection calibration information on the basis of information feedback. The method includes the steps of 1) adjusting a projector and a projection screen to locate at preset positions and directions, then executing the step 2); 2) calibrating a projected image by a main controller, adjusting edges and integration borders to enable the image to be fit with the screen, and then executing the step 3); 3) acquiring specific information about the projected image by a camera, and the like. The device for processing projection calibration information on the basis of information feedback comprises the main controller, the projector, the camera, the projection screen and a user terminal. The main controller is connected with the projector, the camera and the user terminal respectively, and the projector and the camera are arranged in alignment to the projection screen. Compared with the prior art, the method and the device have the advantages that cost is lower, operation is more convenient, and positioning data is more accurate and the like.
Owner:SHANGHAI HUABO INFORMATION SERVICE
Multi-source sensor fusion positioning method and device
PendingCN112556690AAvoid defectsImprove usabilityNavigation by speed/acceleration measurementsSatellite radio beaconingData packControl system
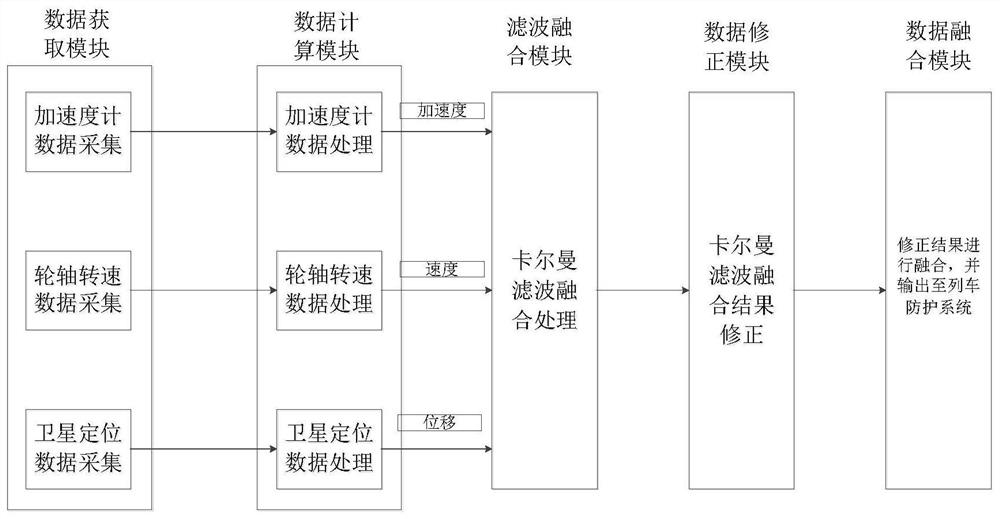
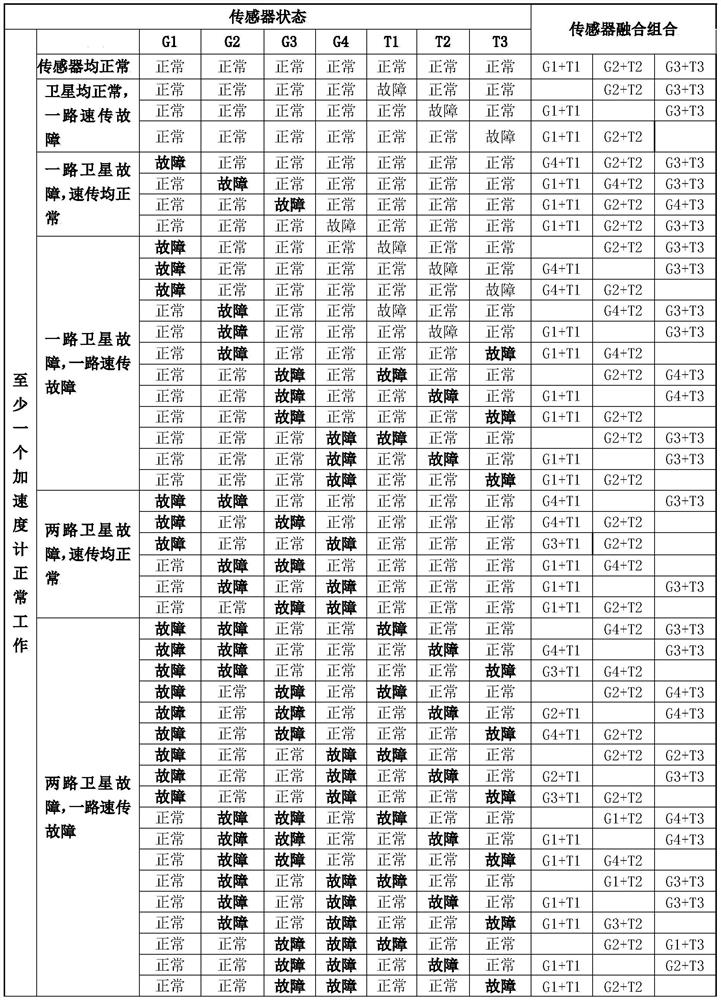
The invention provides a multi-source sensor fusion positioning method and a multi-source sensor fusion positioning device. The multi-source sensor fusion positioning method comprises the following specific steps: acquiring data of a plurality of sensors of a train; calculating the data acquired by the sensor to obtain a corresponding data packet; performing Kalman filtering fusion on the data packets from the plurality of sensors, and selecting a fusion data combination output to the outside by the sensors from predefined fusion data combinations of the plurality of sensors according to the actual operation state of each sensor; correcting the fused data based on the sampling period of each sensor; and performing secondary fusion on the corrected fusion data, and outputting a fusion result to a train protection system. According to the invention, period consistency processing and filtering fusion are carried out on data measured by multiple sensors, and then a fusion result is corrected according to the sampling period of the fusion data, so that the positioning availability of the train control system is improved, the defects of each sensor are avoided, and the train speed and the displacement information accuracy are ensured.
Owner:CRSC RESEARCH & DESIGN INSTITUTE GROUP CO LTD
Merchant positioning system for electronic coupon and issue and positioning method of merchant positioning system
InactiveCN107451849AEasy to usePositioning data is accurateDiscounts/incentivesComputer terminalPositioning system
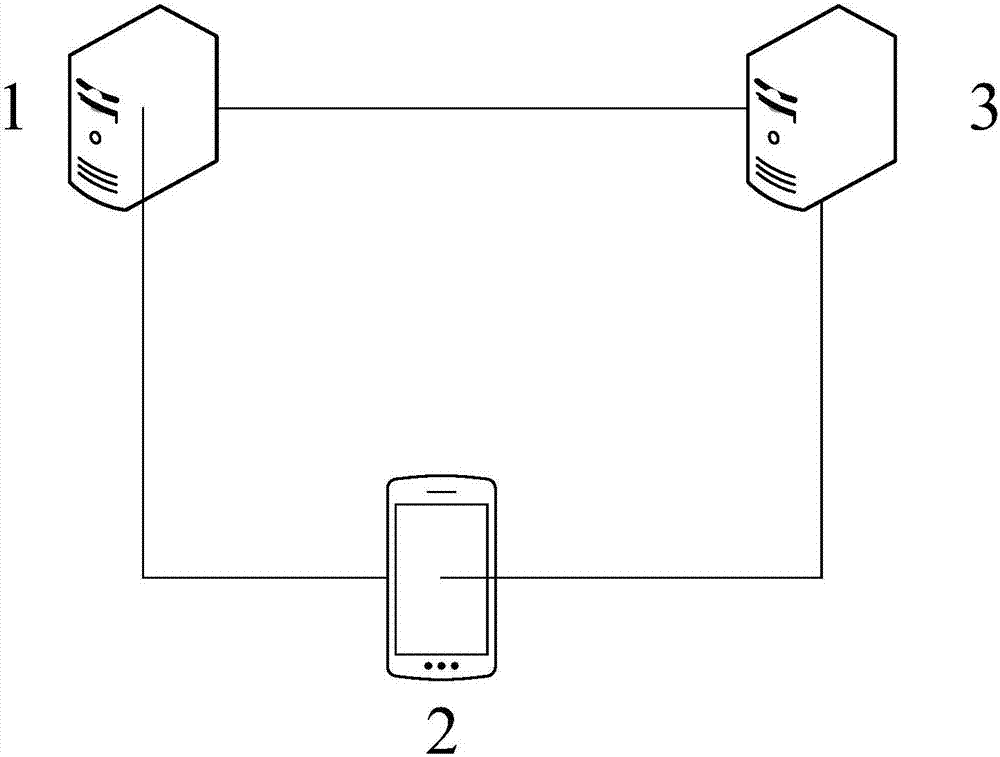
The invention relates to a business positioning system for electronic coupons and a coupon issuing and positioning method thereof. Wherein the merchant positioning system includes: an electronic coupon generating device for generating electronic coupons; a mobile terminal connected with the electronic coupon generating device for receiving and displaying electronic coupons and obtaining user location data; a store positioning device for respectively It is connected with the mobile terminal and the electronic coupon generating device, and is used to send the store closest to the user to the mobile terminal according to the user's location data and electronic coupons. Compared with the prior art, the present invention obtains the user's location through the mobile terminal, and pushes the nearest store to the mobile terminal based on the location, so that the most suitable store can still be selected even when there are many stores, which facilitates the use of electronic coupons.
Owner:知而行(上海)企业发展有限公司
Control device for ground transport vehicle
PendingCN107728624AReduce the numberAvoid errorsPosition/course control in two dimensionsBlind zoneIn vehicle
The invention discloses a control device for a ground transport vehicle. The device comprises an ultrasonic automatic following receiving system and an AGV system; the ultrasonic automatic following receiving system is fixed to a ceiling of a needed indoor space, the AGV system can move on the ground of a warehouse, the ultrasonic automatic following receiving system comprises multiple single ultrasonic receiving systems, the AGV system comprises multiple single AGV systems, and the ultrasonic automatic following receiving system can receive signals of ultrasonic sending system ultrasonic sending units in the AGV system. Accordingly, the phenomena of errors caused by wave loss and limitation of a blind area can be avoided, the positioning range of each ultrasonic receiving system is wider,positioning data is more accurate, and the reliability is high; a vehicle-mounted display screen can display the location, speed and local obstacle information in real time; meanwhile, an obstacle avoidance system is adopted, and the error-tolerant rate is increased; the whole system performance is stable, and the running cost and maintenance cost are low.
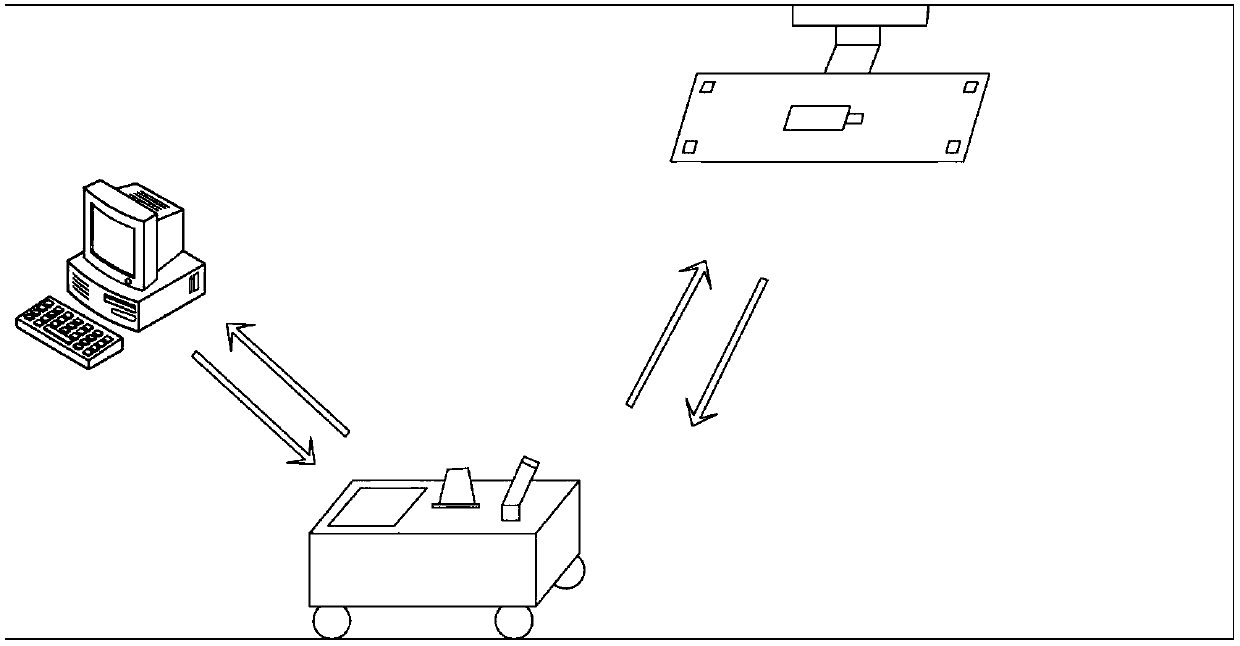
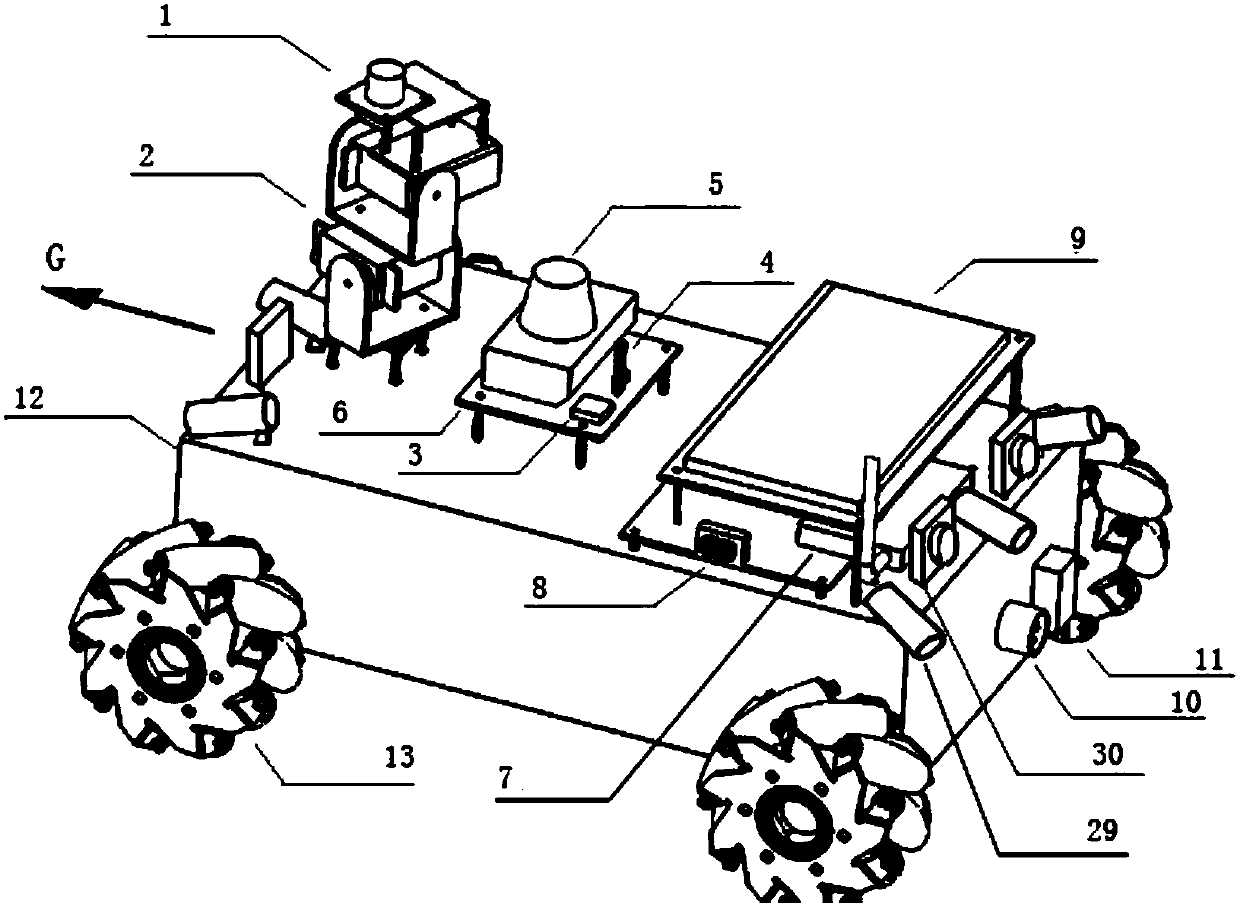
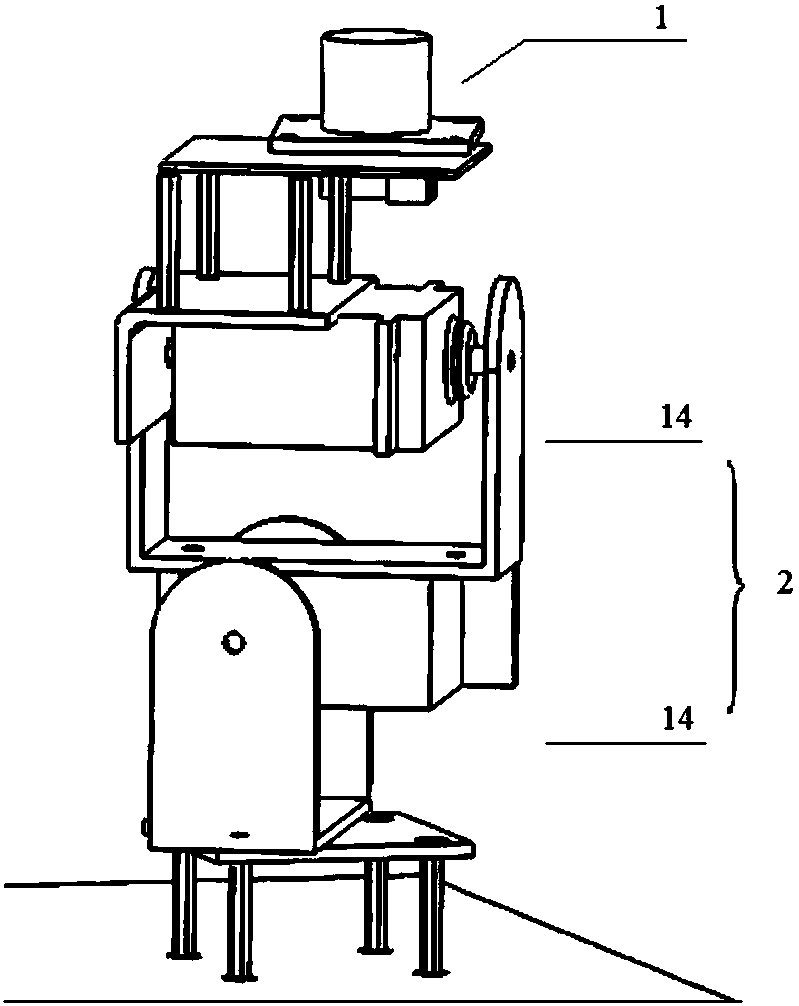
Owner:HEBEI UNIVERSITY OF SCIENCE AND TECHNOLOGY
Indoor wireless positioning method and system
ActiveCN108459300APositioning data is accurateHigh positioning accuracyPosition fixationRadio frequency signalSignal strength
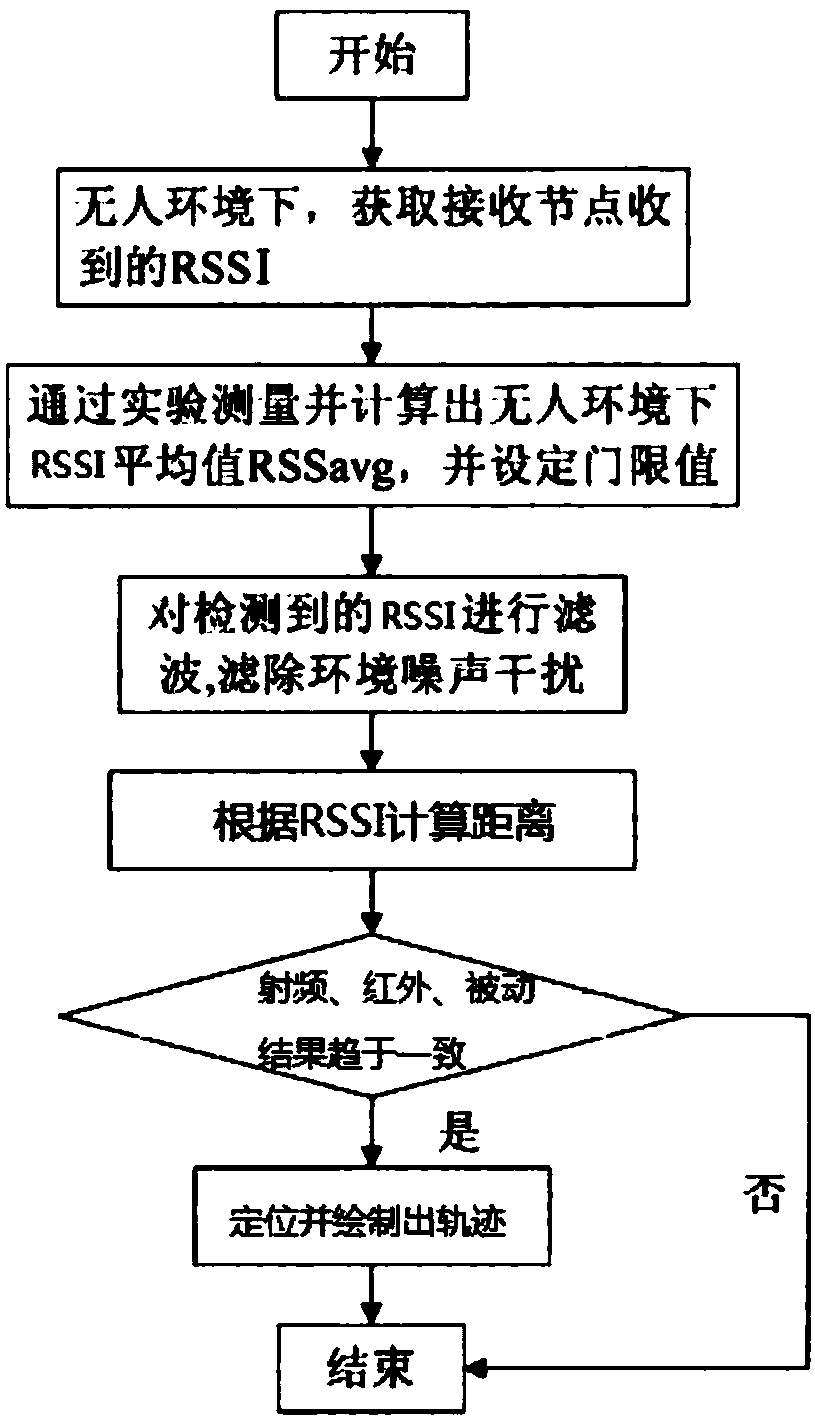
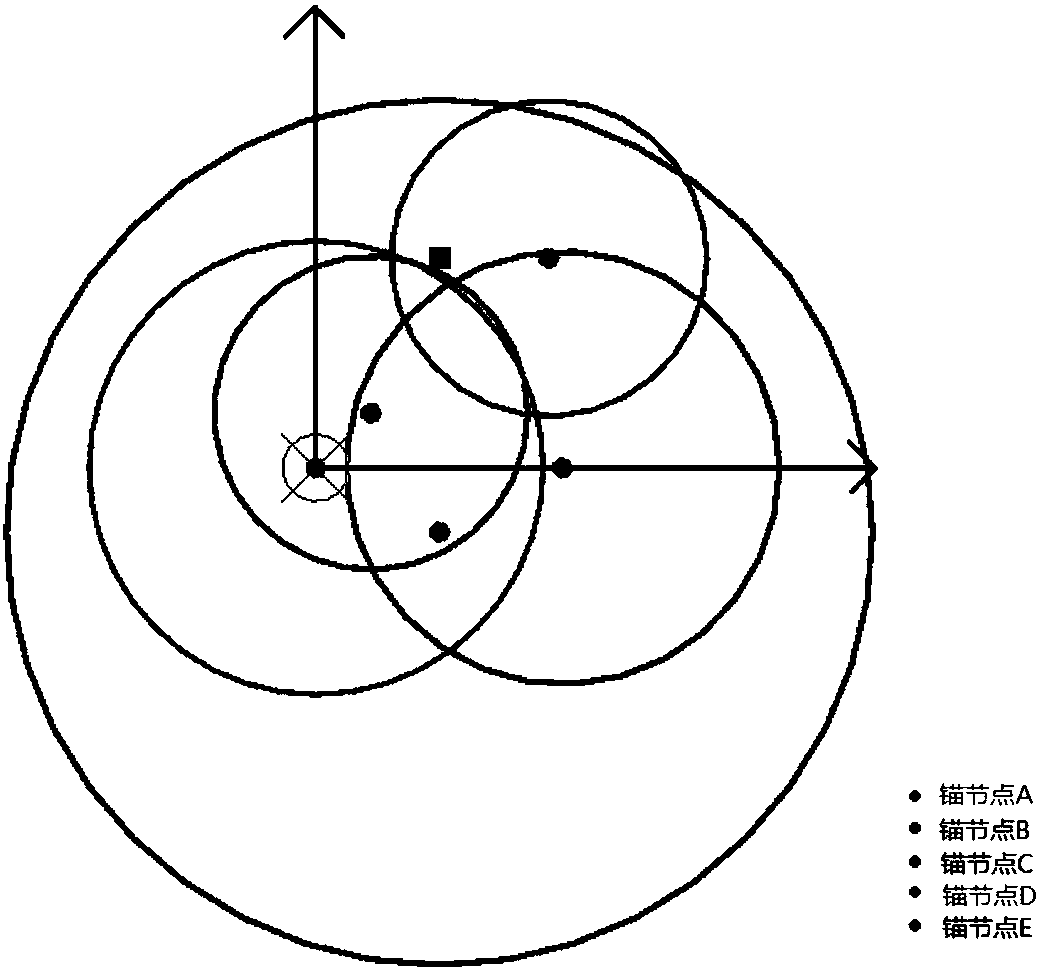
The invention discloses an indoor wireless positioning method and system. The method is characterized by arranging a plurality of fixed anchor nodes indoor, and arranging a mobile node on a target tobe positioned, wherein the mobile node is used for sending a radio-frequency positioning signal to the anchor nodes; obtaining radio frequency signal intensity RSSI received by each anchor node, and carrying out filtering processing on the RSSI; according to the radio frequency signal intensity RSSI obtained after filtering processing, calculating distance value between the mobile node and each anchor node, and comparing the distance values with infrared communication distance and rejecting the distance values, which are not within the infrared communication distance range; according to the distance value between the mobile node and each anchor node and the position of each anchor node, calculating the position of the mobile node within a certain time, and drawing a moving path of the mobile node; according to the moving path of the mobile node, calculating speed [delta]s of the mobile node and correcting the RSSI by utilizing the [delta]s; and calculating the distance between the mobile node and each anchor node by utilizing the corrected RSSI, and based on the calculated distance, determining the position of the mobile node.
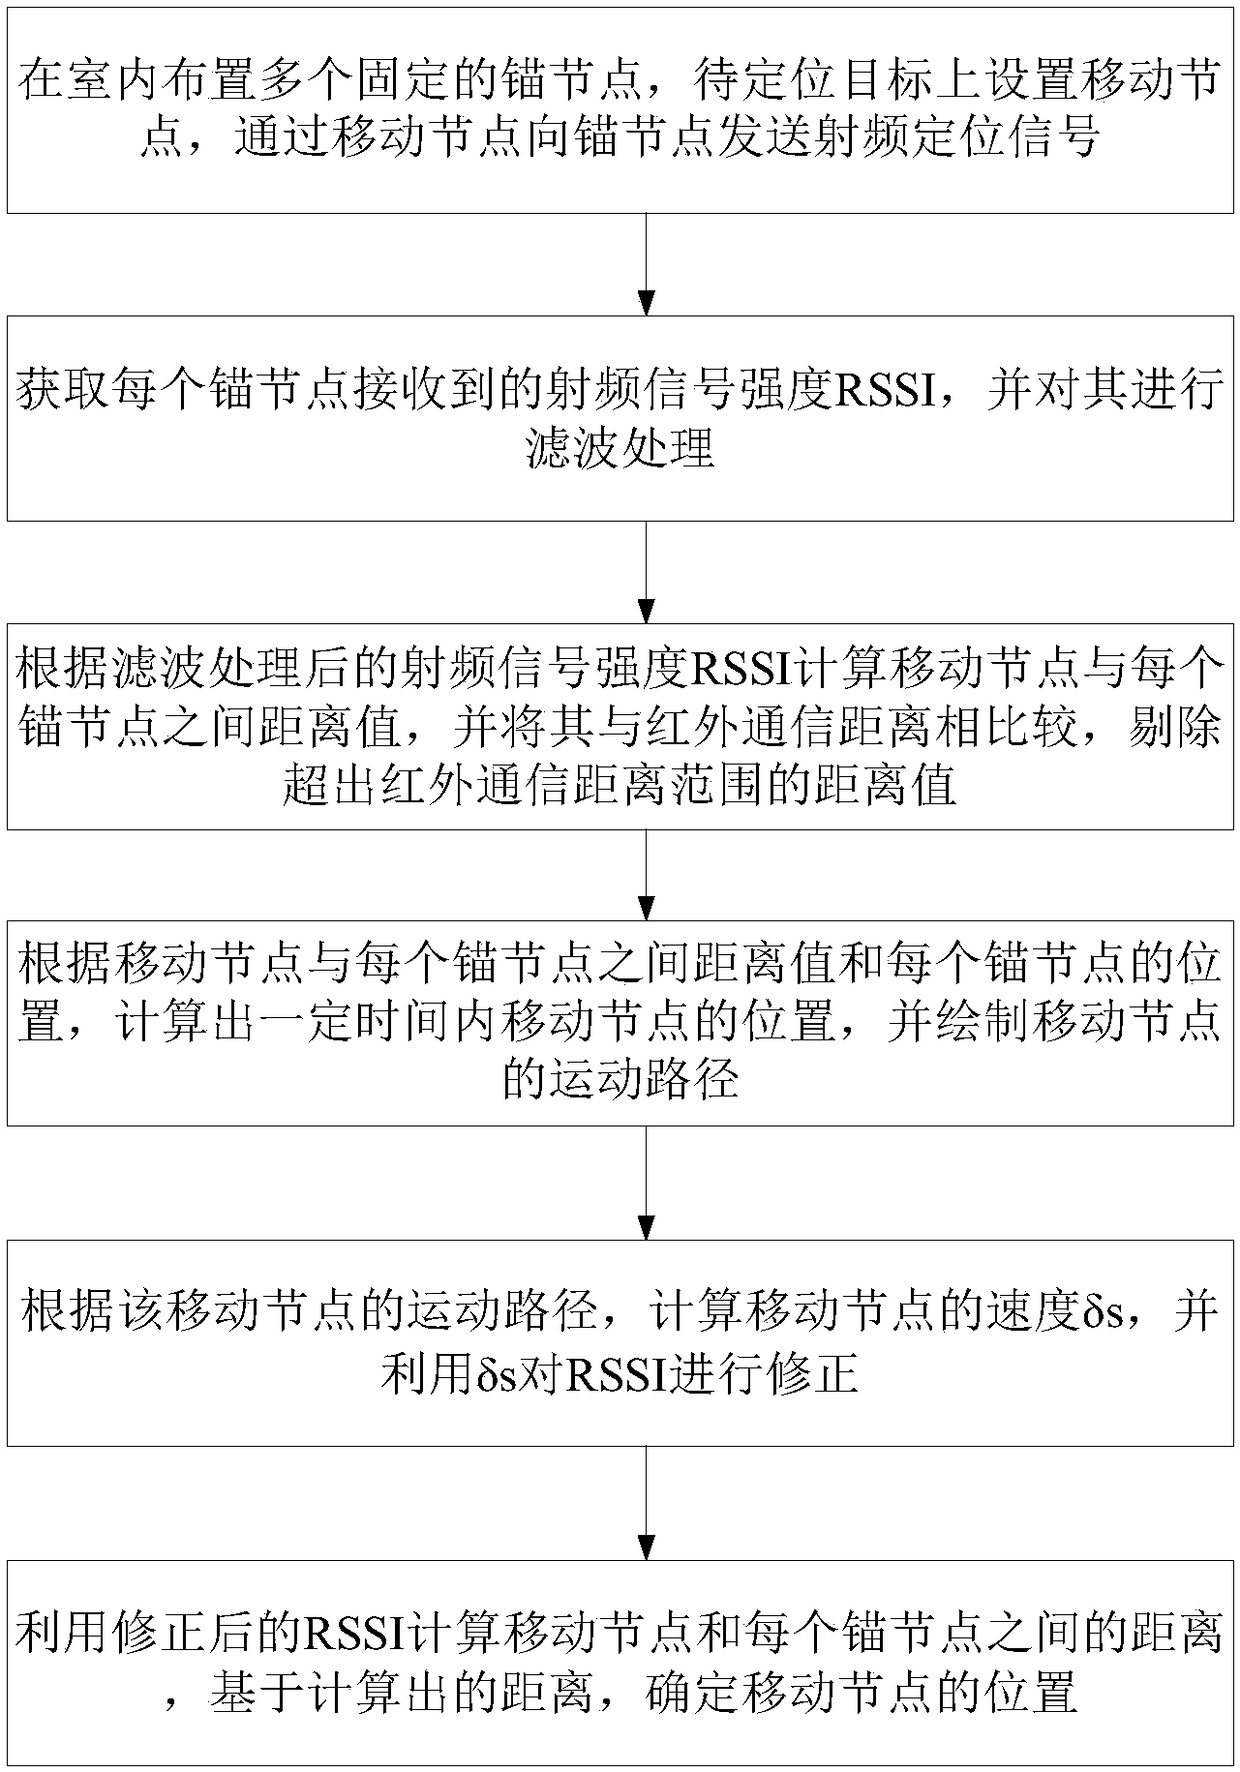
Owner:SHANDONG UNIV
Gyroscope-based GPS packet capture time interval determination method during curve driving process
ActiveCN107505639AEnsure driving safetyPositioning data is accurateSatellite radio beaconingDriving safetyAngular velocity
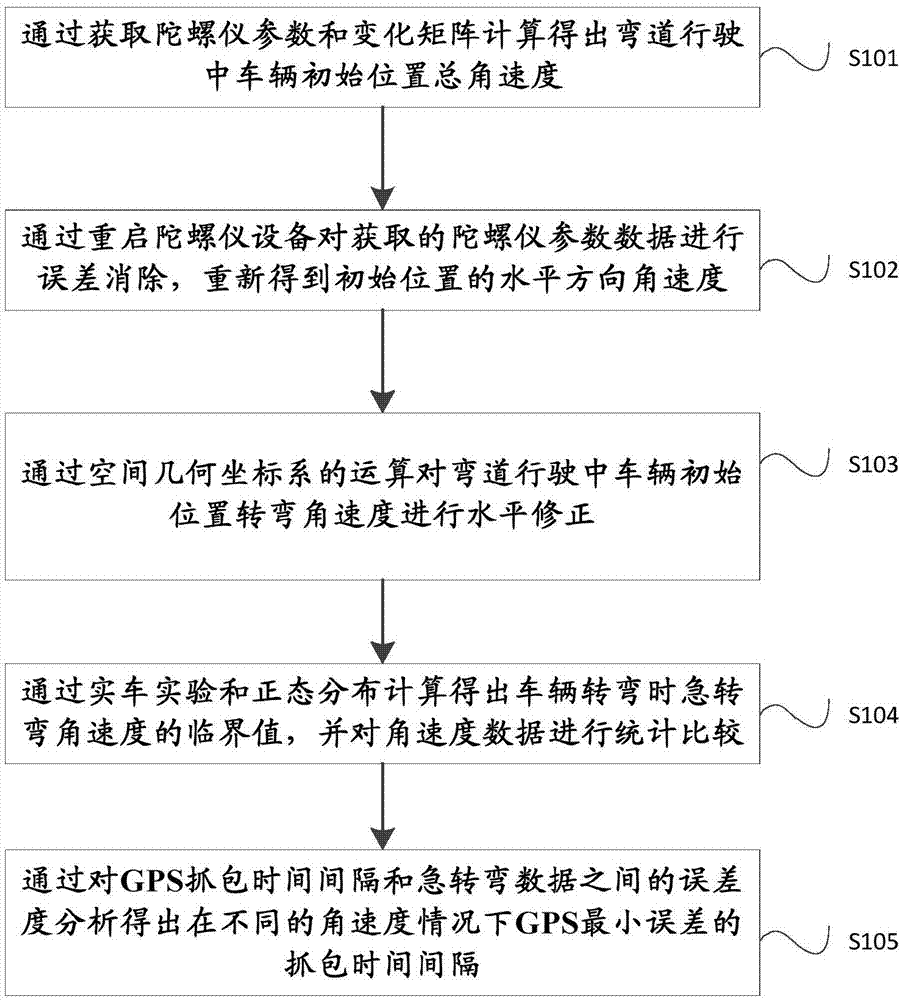
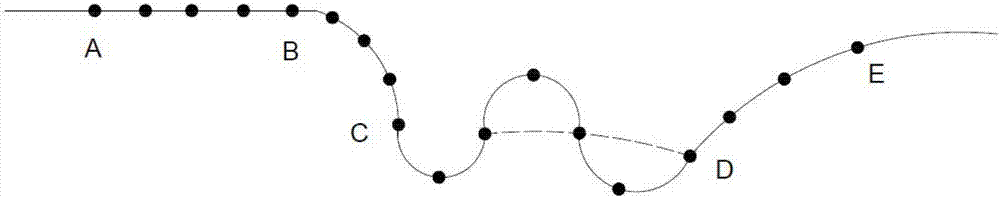
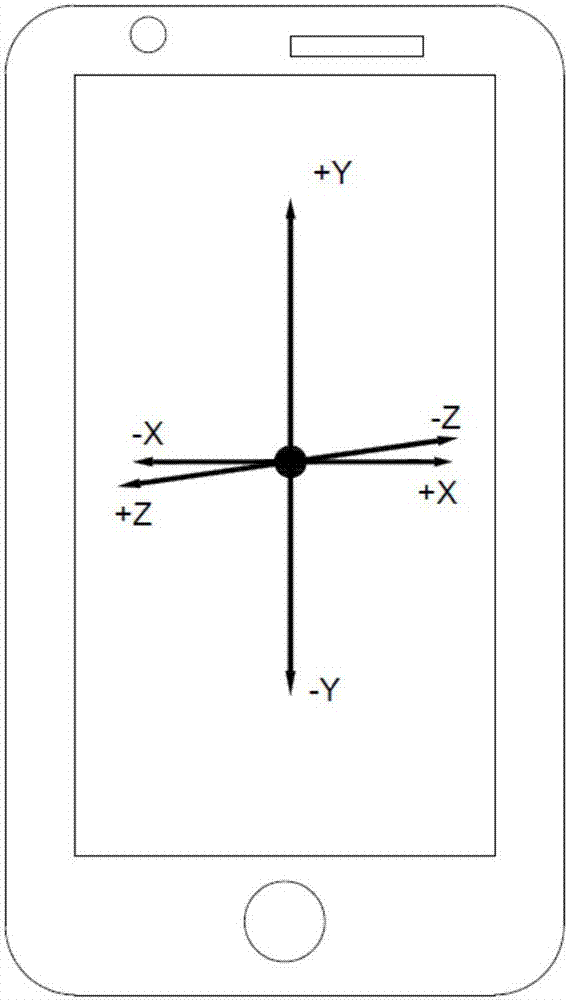
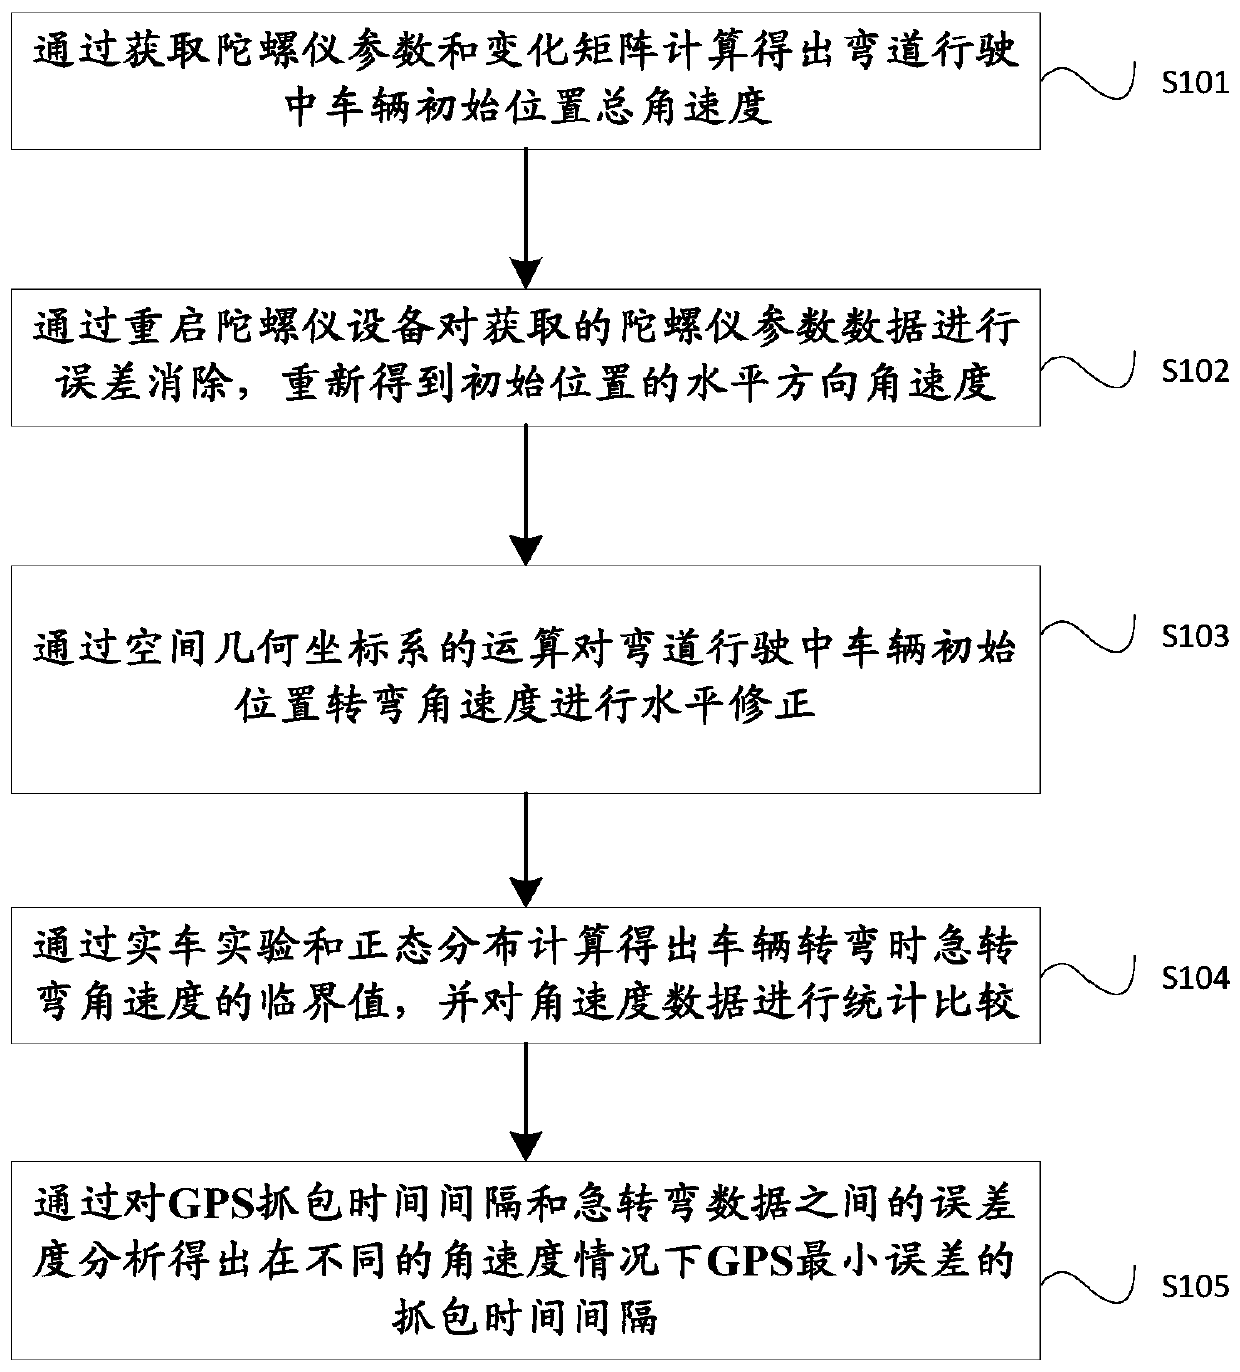
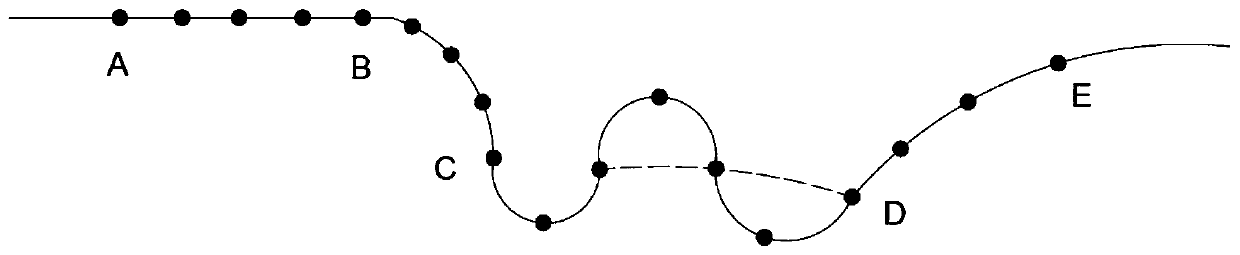
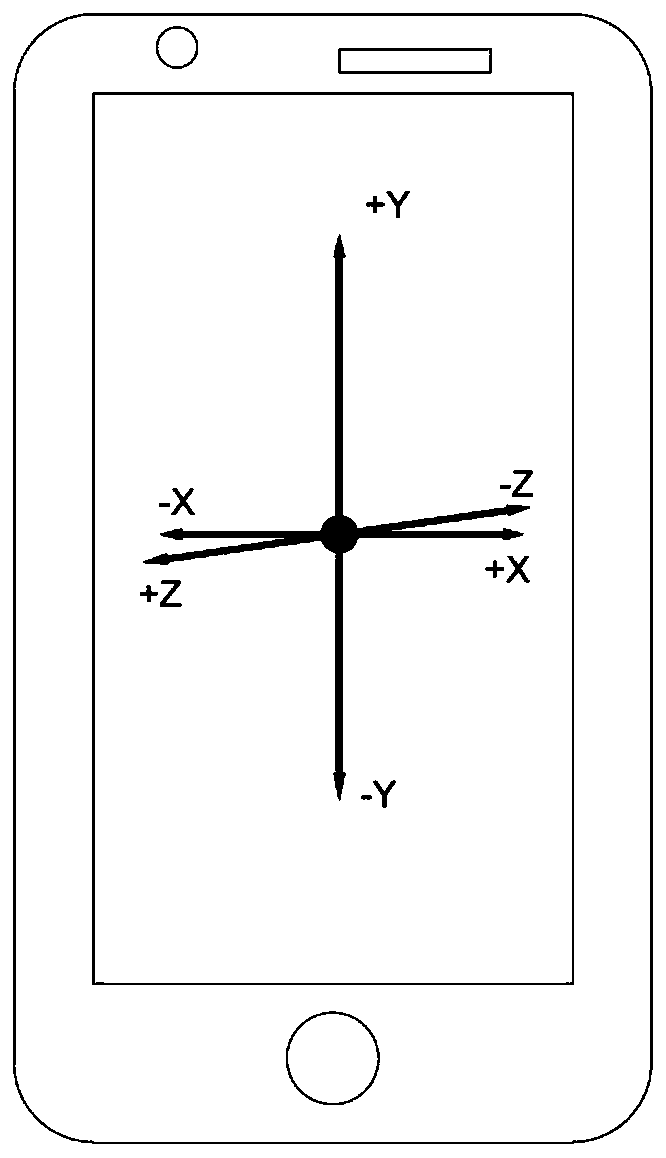
The present invention relates to a gyroscope-based GPS packet capture time interval determination method during a curve driving process. The method comprises the steps of obtaining the parameters of a gyroscope and a change matrix to calculate the total angular velocity at a vehicle initial position during the curve driving; restarting the gyroscope to eliminate the error of the obtained gyroscope parameter data, and obtaining the horizontal direction angular velocity at the initial position again; carrying out the horizontal correction on the turning angular velocity at the vehicle initial position during the curve driving by the operation of a spatial geometric coordinate system; obtaining the critical value of the sharp turning angular velocity at vehicle turning by a real vehicle experiment and the normal distribution calculation, and gathering and comparing the angular velocity data; analyzing the degree of error between the GPS packet capture time interval and sharp turning data to obtain the packet capture time interval of a GPS minimum error on different angular velocity conditions. The method of the present invention can remind the users to decelerate timely during the driving process, guarantees the curve driving safety, at the same time, enables a mobile phone APP to obtain the positioning data more accurately.
Owner:小花网络科技(深圳)有限公司
Target positioning method and device for mobile robot
PendingCN119596234Aprecise positioningPositioning data is accurateNavigational calculation instrumentsPosition fixationUltra-widebandEngineering
The invention discloses a target positioning method and device for a mobile robot, a storage medium and electronic equipment. The method comprises the following steps: acquiring base station distribution information in the ultra-wideband positioning system; the ultra-wideband positioning system comprises a base station and a label, constructing a TDOA positioning equation based on the base station distribution information, and performing secondary estimation on the TDOA positioning equation through a Chan algorithm to obtain an initial coordinate value of the tag; taking the initial coordinate value as an initial value of Taylor series, and obtaining a coordinate correction value of the label through Taylor; calculating a label error value based on the coordinate correction value of the label; and when the label error value is smaller than a preset error threshold value, outputting a label coordinate estimation value, filtering the label coordinate estimation value through a Kalman filtering algorithm to obtain a label coordinate optimal estimation value, and taking the label coordinate optimal estimation value as a target position. The method can improve the positioning range and effect, and enables the positioning data to be more accurate.

Owner:HUBEI UNIV OF ARTS & SCI +1
GPS drift data filtering method and system, and terminal
ActiveCN107884793APositioning data is accurateSatellite radio beaconingWireless communicationShortest distanceComputer terminal
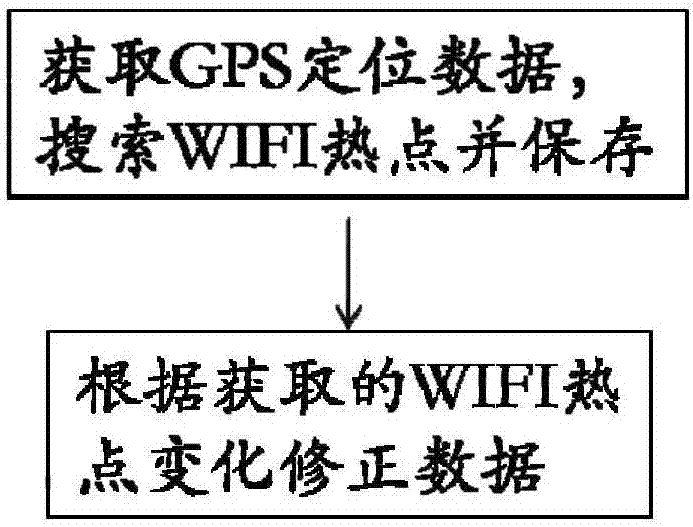
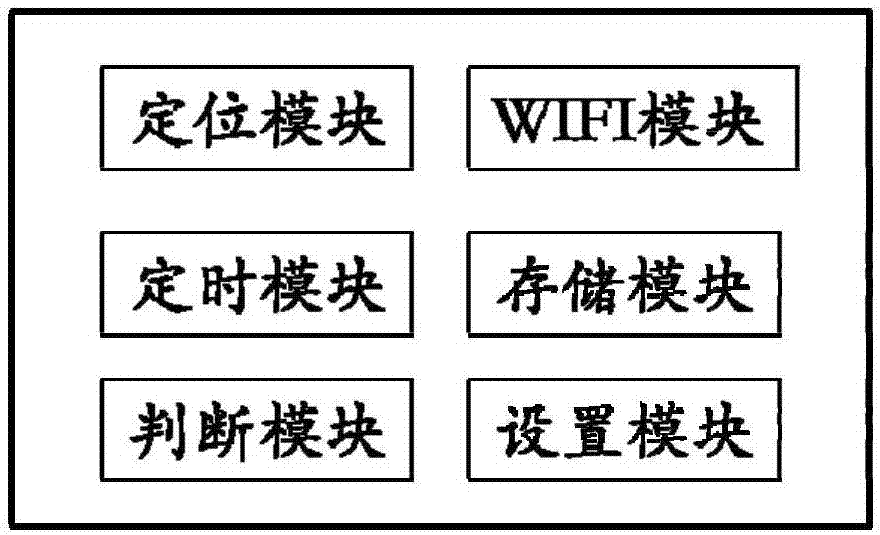
The invention discloses a GPS drift data filtering method and system, and a terminal. The method comprises: acquiring GPS positioning data, searching for a WIFI hotspot and storing the hotspot; and correcting positioning data according to the change of the acquired WIFI hotspot. Because the GPS data are corrected by using the WIFI hotspot, when a user carries a GPS filter terminal and moves in anenvironment with a WIFI signal, short-distance GPS drift data can be filtered, so that the accuracy of positioning data is improved.
Owner:XIAMEN YAXON NETWORKS CO LTD
Vehicle positioning data acquisition method and device, vehicle-mounted equipment and storage medium
ActiveCN111208546ASmooth and precise driving trajectoryNo driftInstruments for road network navigationNavigation by speed/acceleration measurementsIn vehicleData acquisition
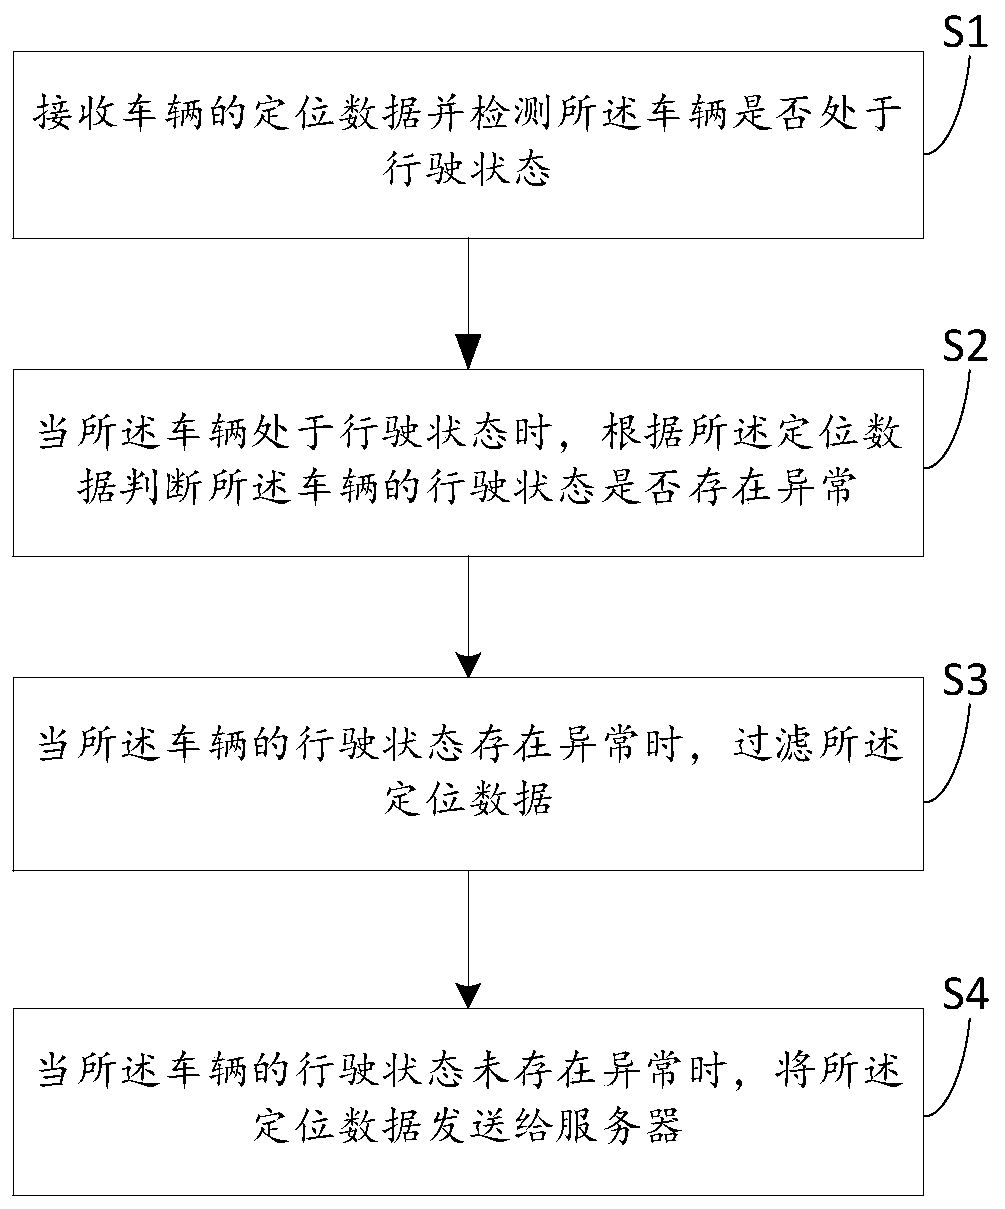
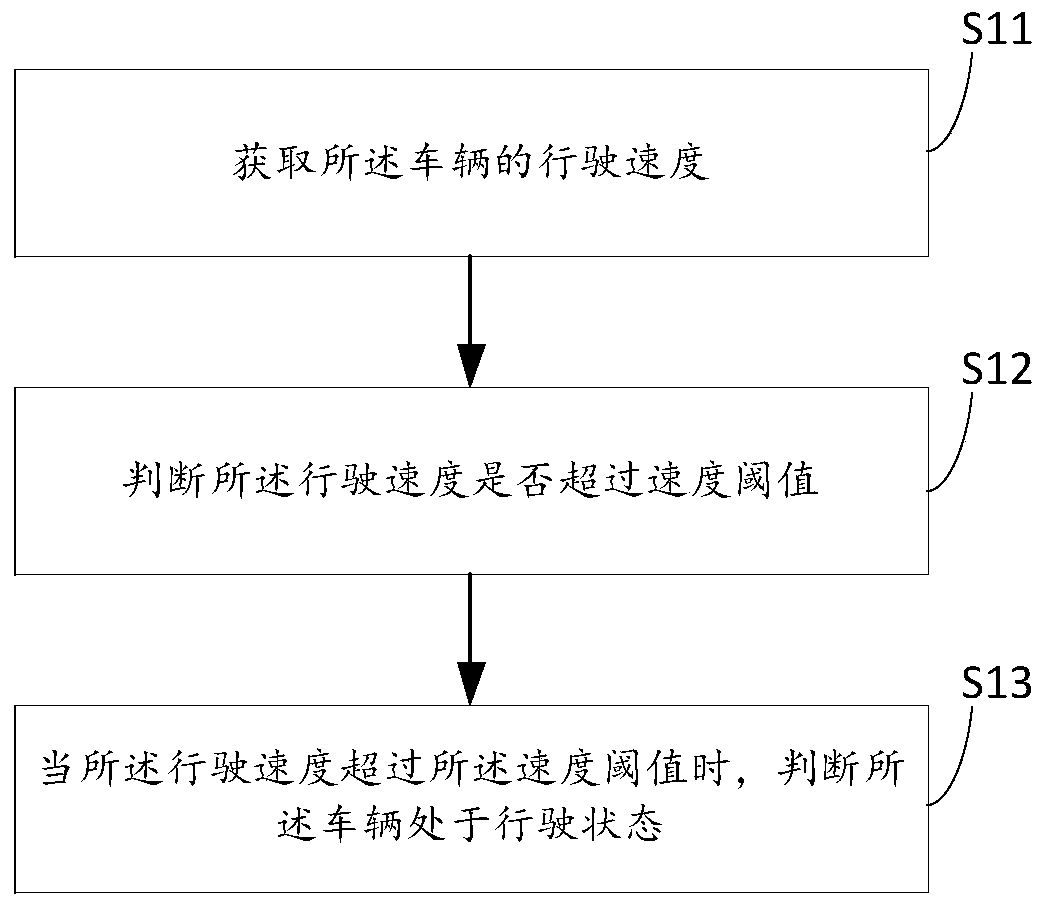
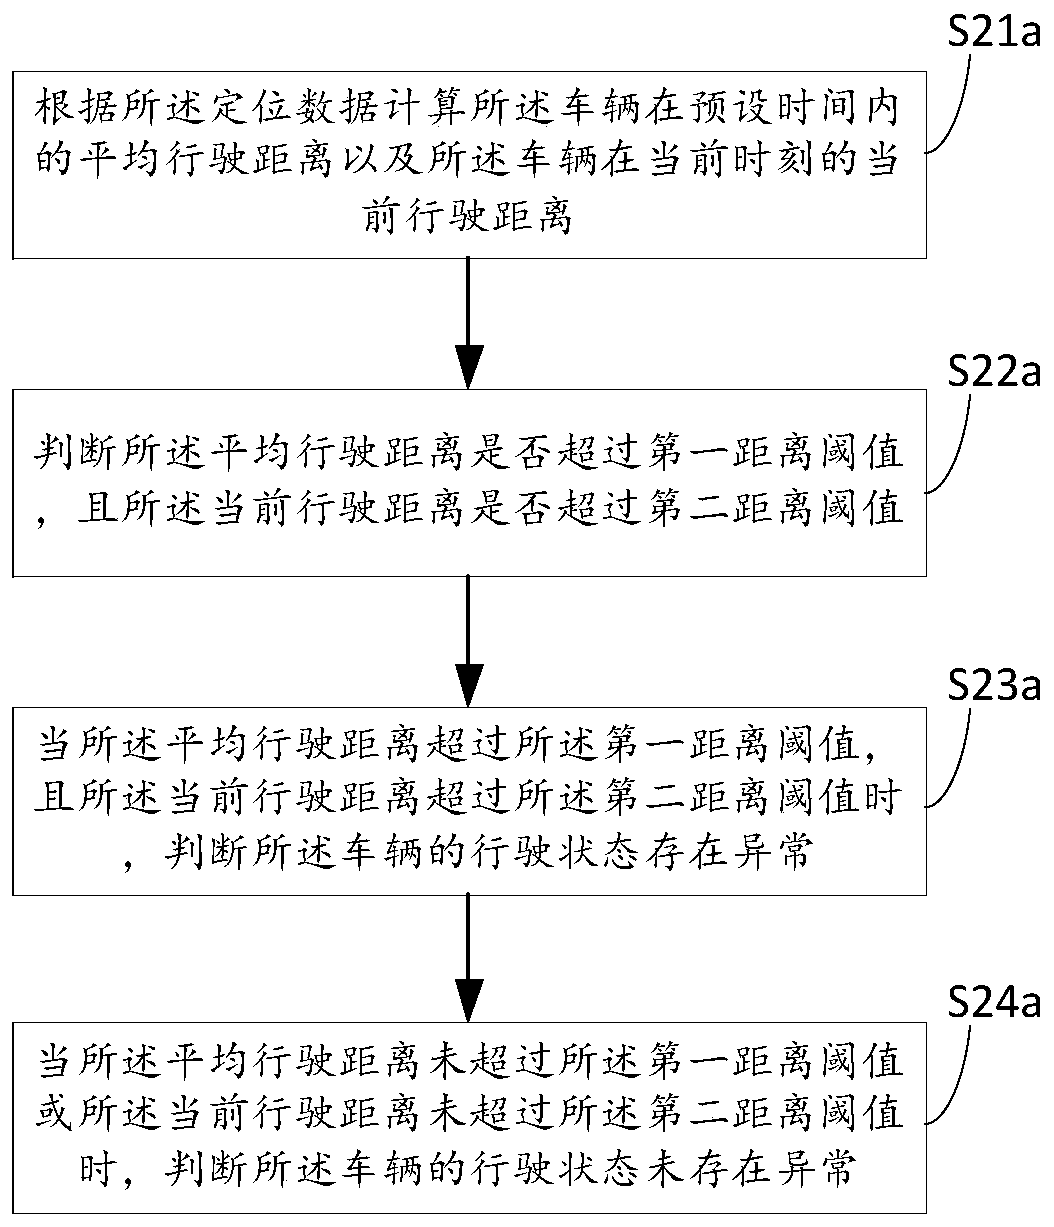
The invention discloses a vehicle positioning data acquisition method and device, vehicle-mounted equipment and a storage medium, and the method comprises the steps: receiving the positioning data ofa vehicle, and detecting whether the vehicle is in a driving state or not; when the vehicle is in the driving state, judging whether the driving state of the vehicle is abnormal or not according to the positioning data; when the driving state of the vehicle is abnormal, filtering the positioning data; and when the driving state of the vehicle is not abnormal, sending the positioning data to a server. According to the method provided by the invention, relatively accurate positioning data can be obtained so that a vehicle driving track formed by the obtained positioning data subsequently does not have a drifting phenomenon and the driving track is smooth and accurate.
Owner:LAUNCH TECH CO LTD
Emergency Beidou weather station and method for acquiring meteorological data
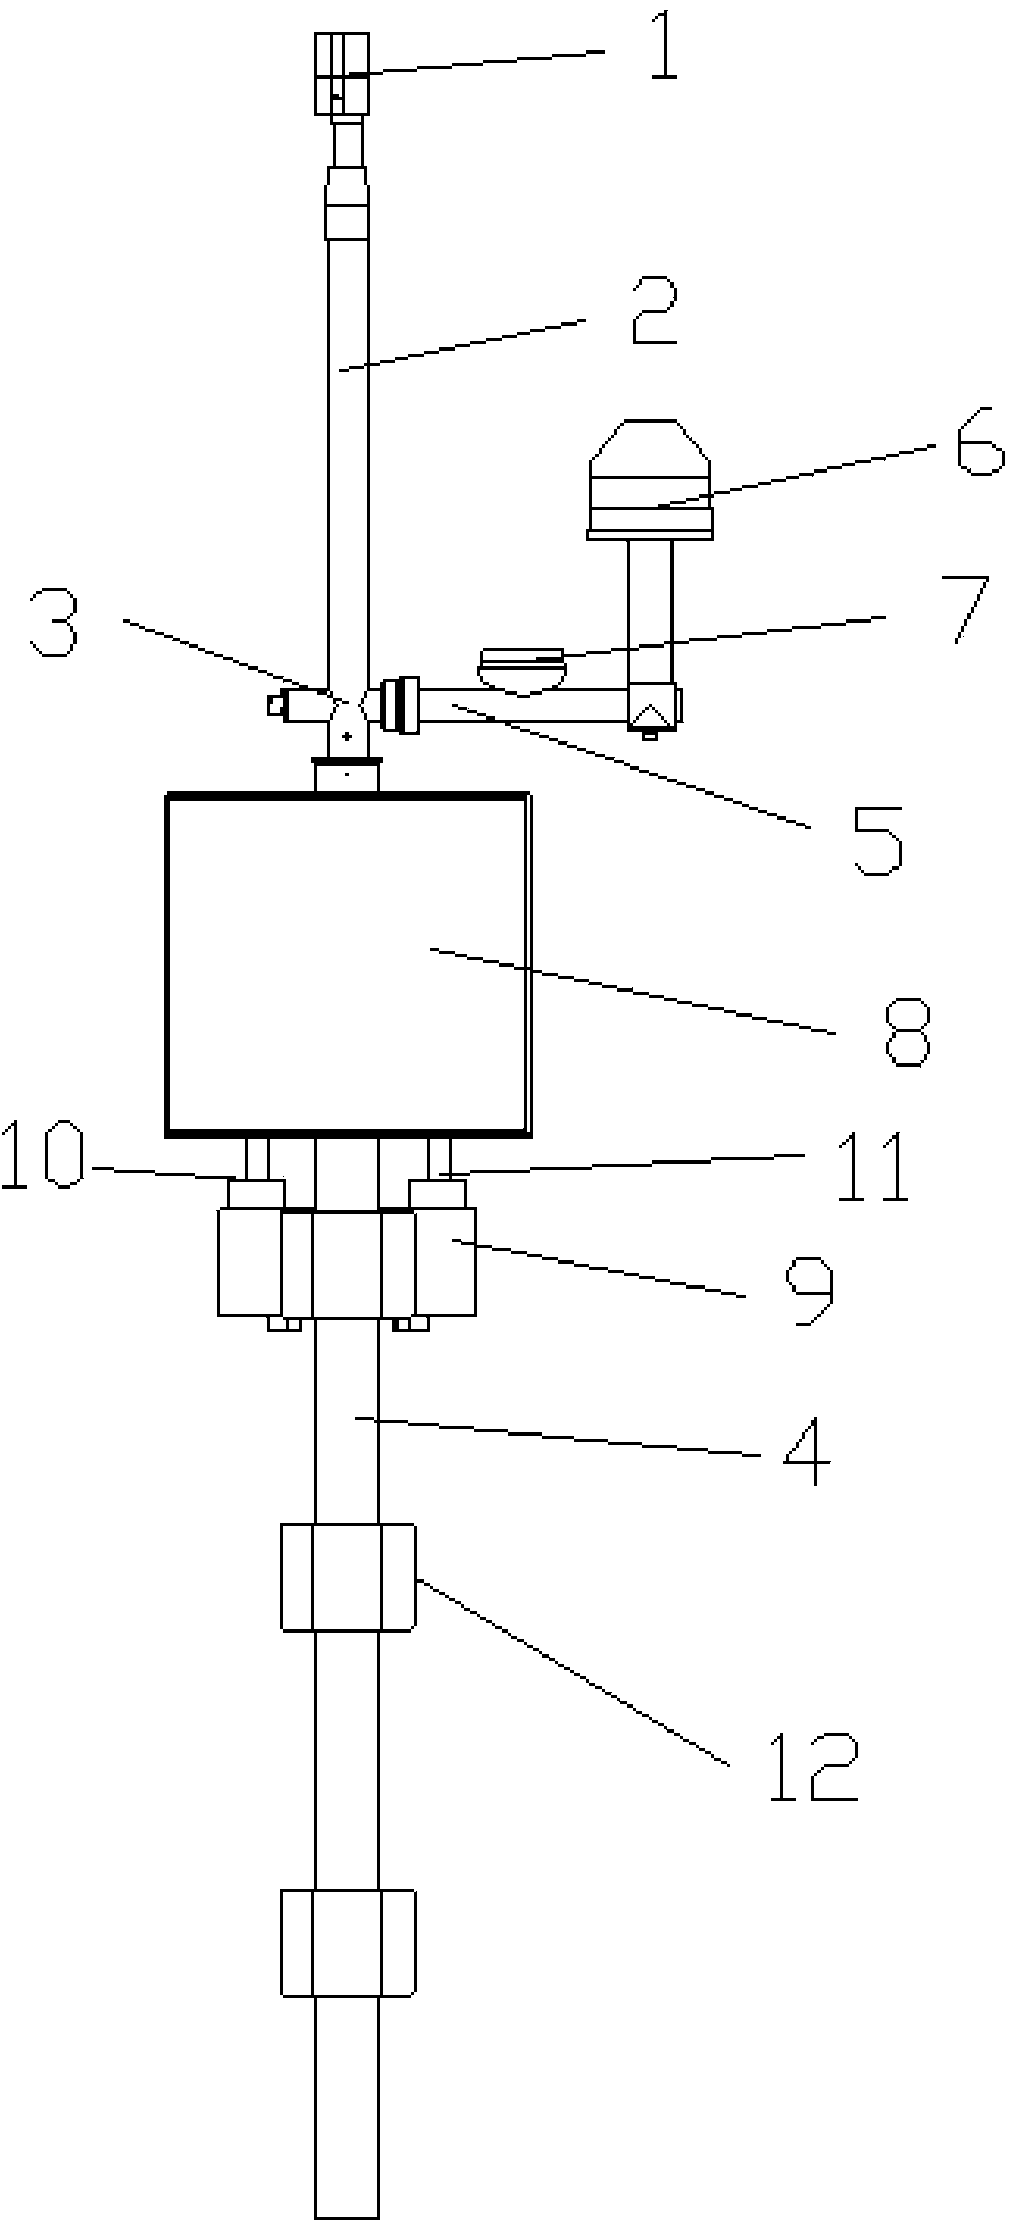
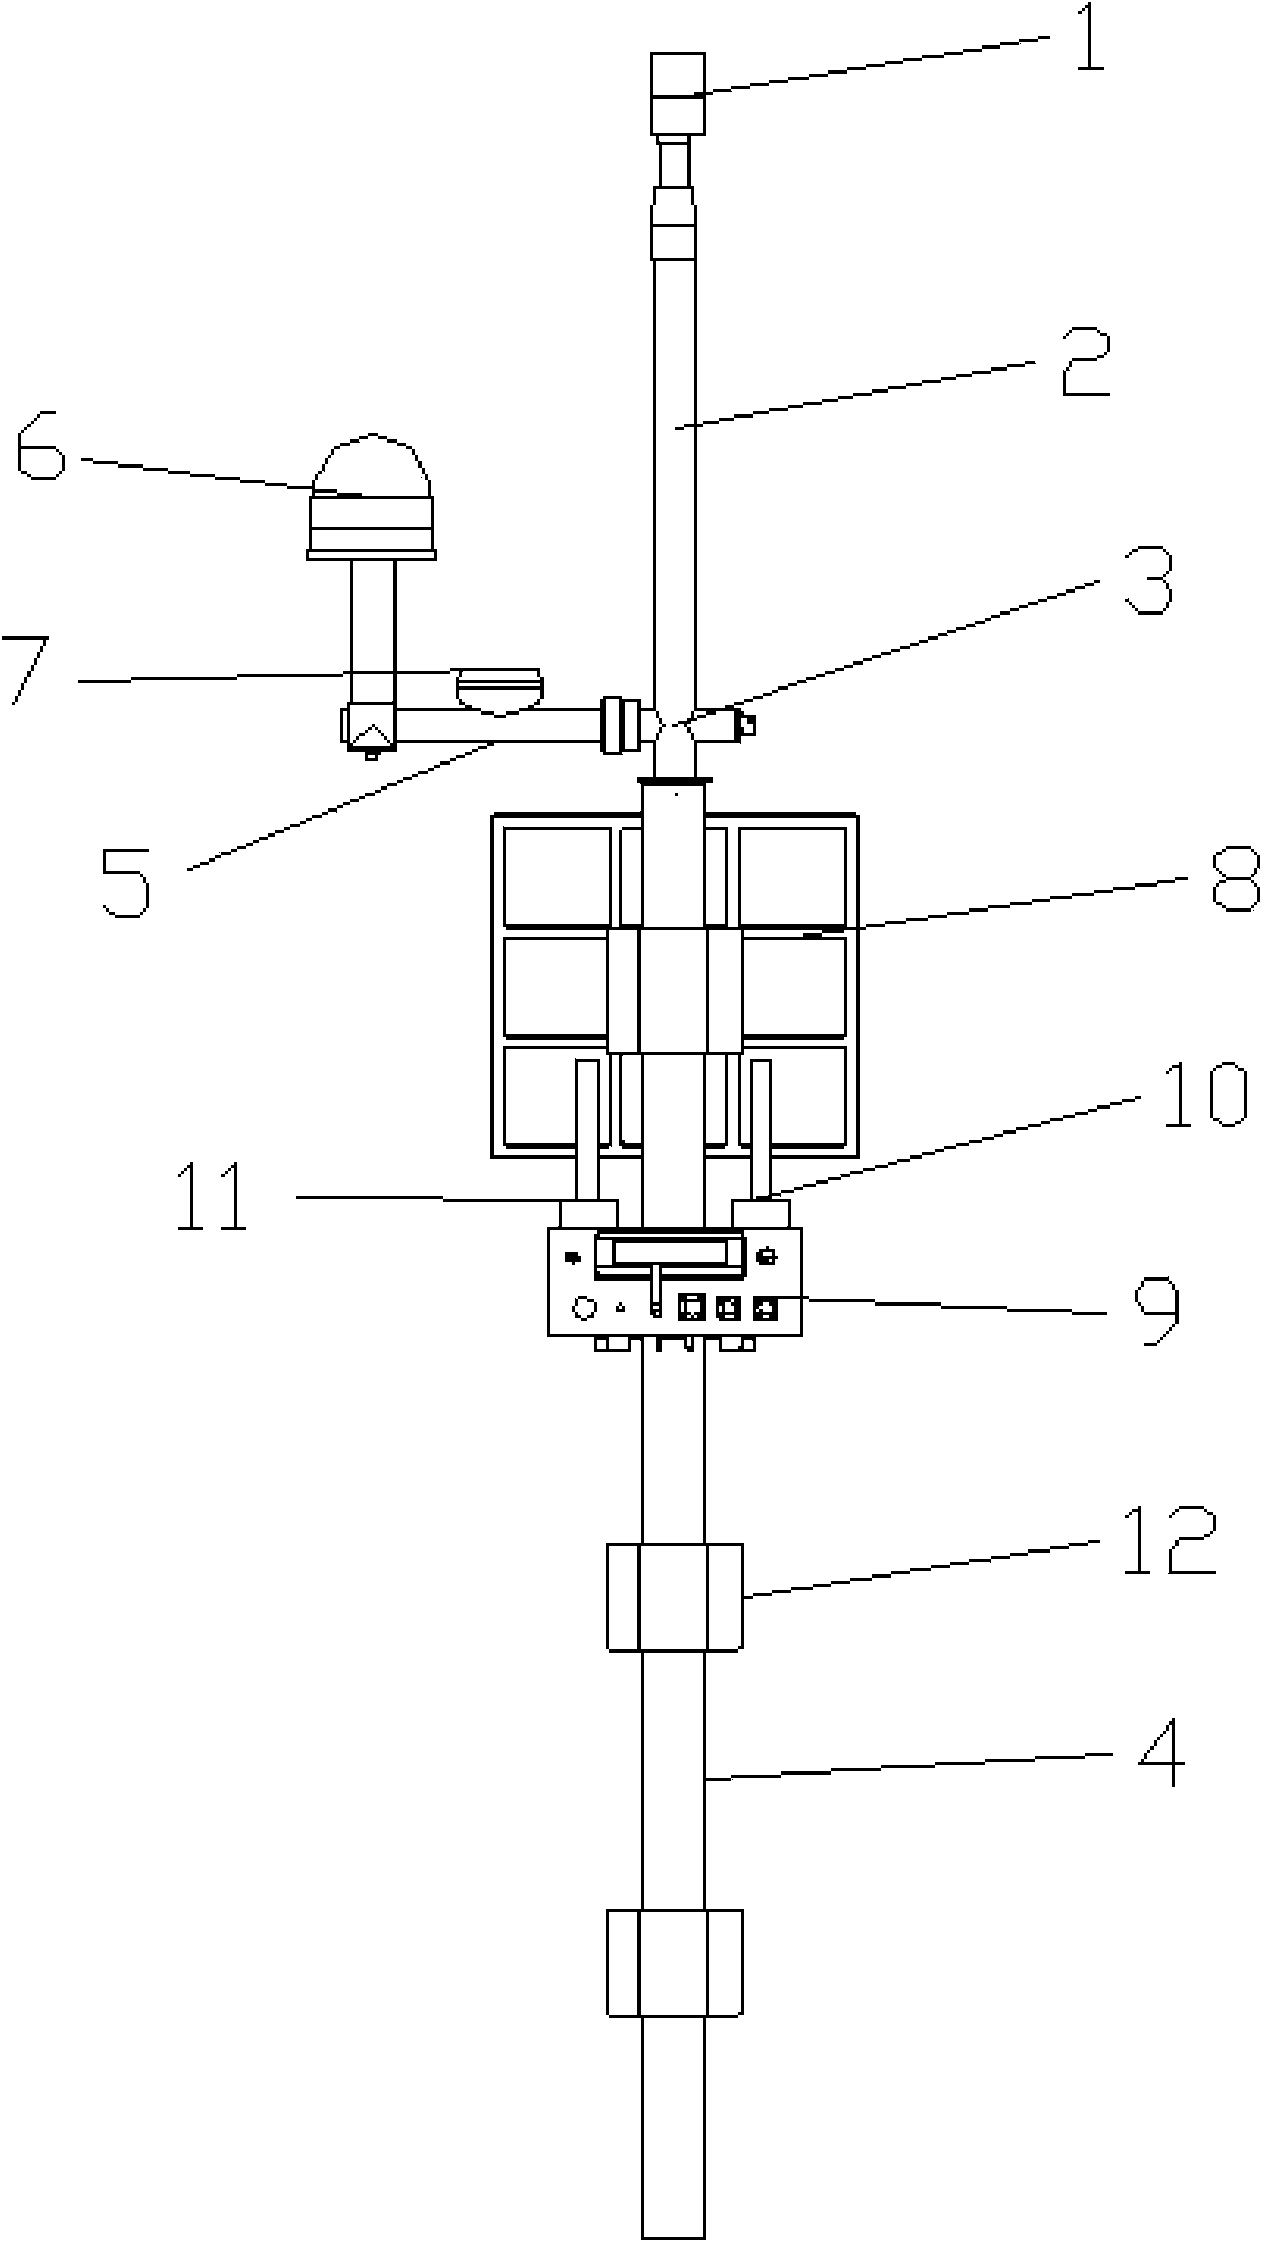
The invention relates to an emergency Beidou weather station and a method for acquiring meteorological data. The emergency Beidou weather station comprises a data acquisition unit, a telescopic hollow tube, a three-way hollow tube, a supporting rod and a positioning north arrow module, wherein the data acquisition unit is arranged at the top end of the hollow tube, the bottom end of the hollow tube is connected with the supporting rod through the three-way hollow tube, and another end of the three-way hollow tube is connected with the positioning north arrow module. A battery power supply system module and a system box are arranged on the supporting rod, a DTU transmission antenna and a Wifi transmission antenna are arranged at the upper end of the system box, and a plurality of fixing devices are arranged on the supporting rod. The weather station is fixed on a member bar of an automobile or a ship through the fixing devices. When a power switch is turned on, the devices are powered on, a system is in an initialization phase, a peripheral sensor device and an automatic data transmission channel are allocated, and data exchange is performed through a PC side and the data acquisition unit. Therefore, the problems that the Beidou weather station is incapable of moving and inconvenient to carry, and data cannot be transmitted in time due to network interruption caused by occurrence of meteorological disasters are solved.
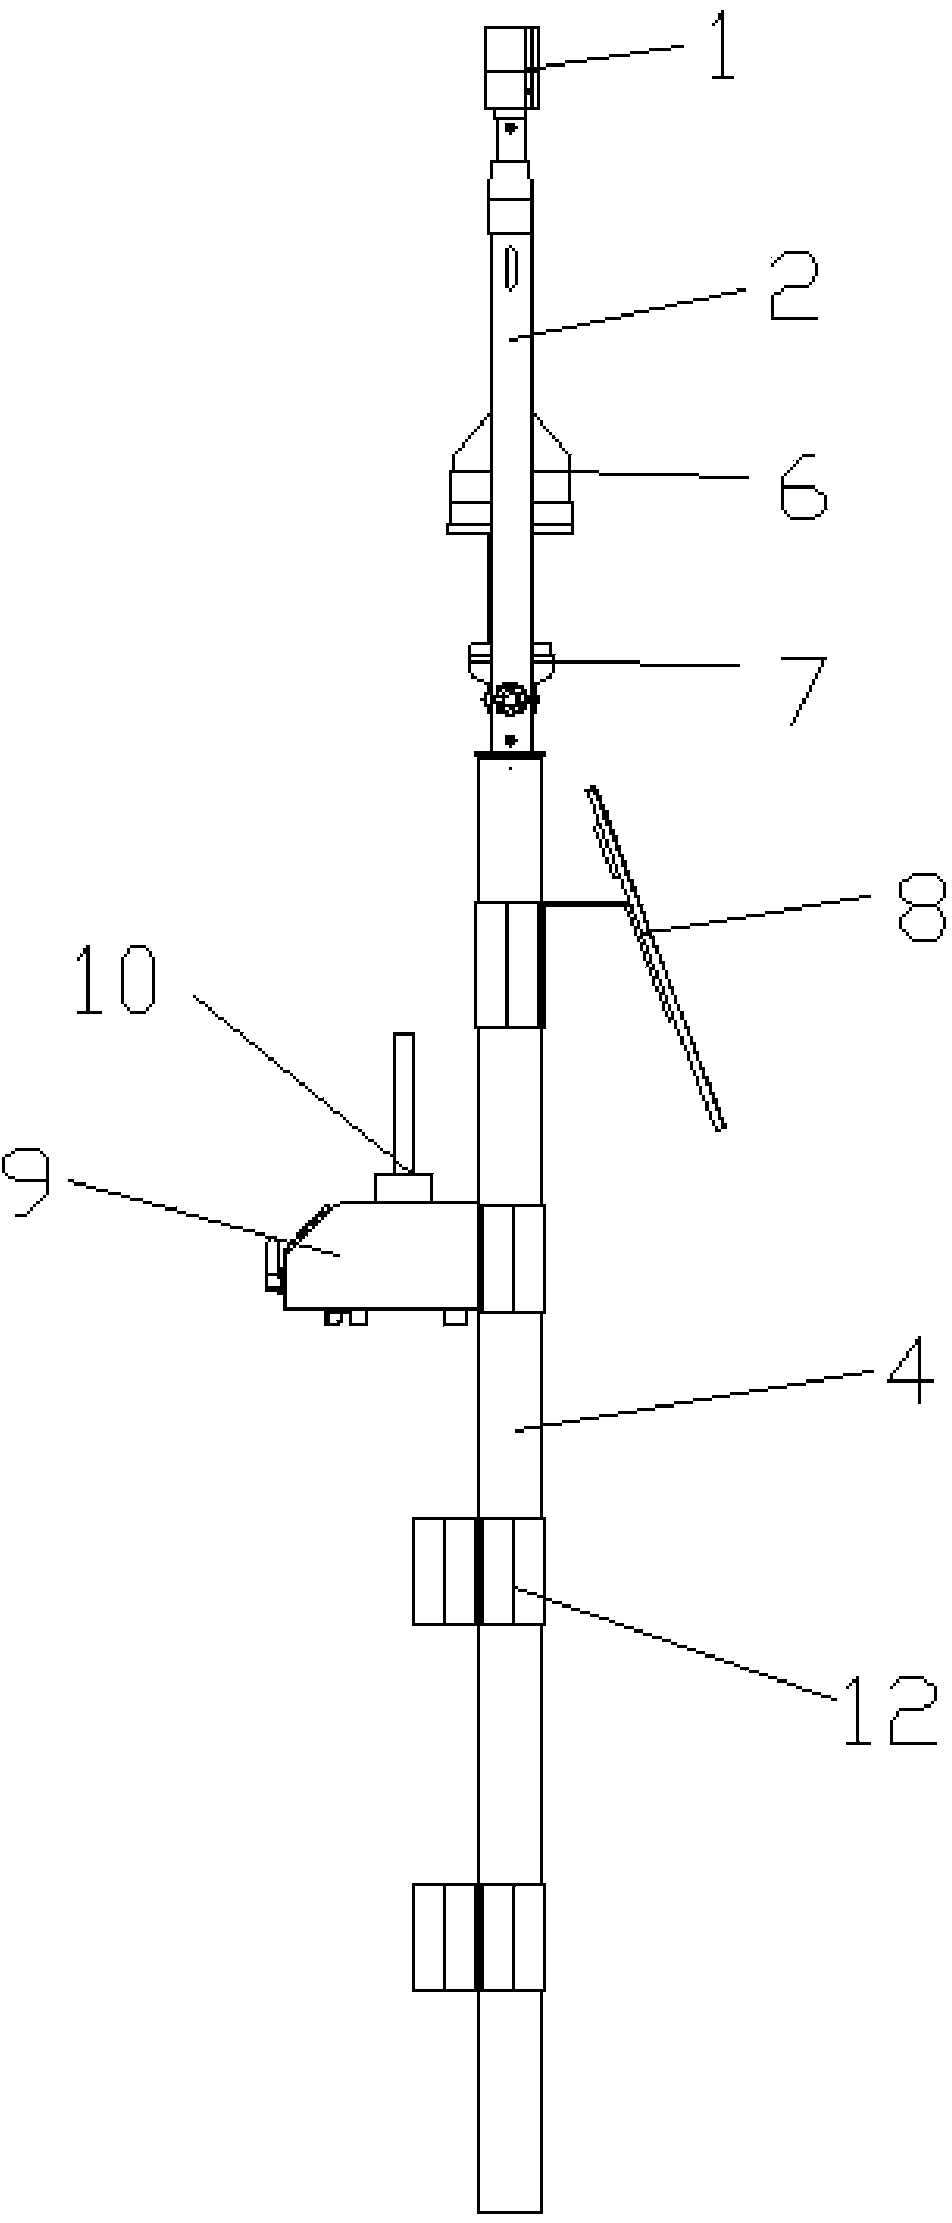
Owner:NANJING CHINA SPACENET SATELLITE TELECOM
Method for selecting global positioning system (GPS) positioning and base station positioning during store visit
ActiveCN102692635BImprove accuracyPositioning data is accurateSatellite radio beaconingLocation information based serviceShortest distanceComputer terminal
The invention relates to a method for selecting global positioning system (GPS) positioning and base station positioning during store visit. The method comprises the following steps of: judging whether the GPS positioning of a handheld terminal is valid or not at first, if the GPS positioning of the handheld terminal is valid, preferably selecting GPS positioning data as valid positioning data and storing the GPS positioning data in a data base, otherwise, selecting base station positioning data as valid positioning data and storing the base station positioning data in the data base; and when the position information of a target store is valid, comparing the distance between a base station positioning position and the position of the target store with the distance between a GPS positioning position and the position of the target store, selecting the shorter distance as the valid positioning data and storing the valid positioning data in the data base. Therefore, by the method, more accurate positioning data can be acquired, the accuracy of store visit tracks is improved, and more valid data is provided for enterprise store management.
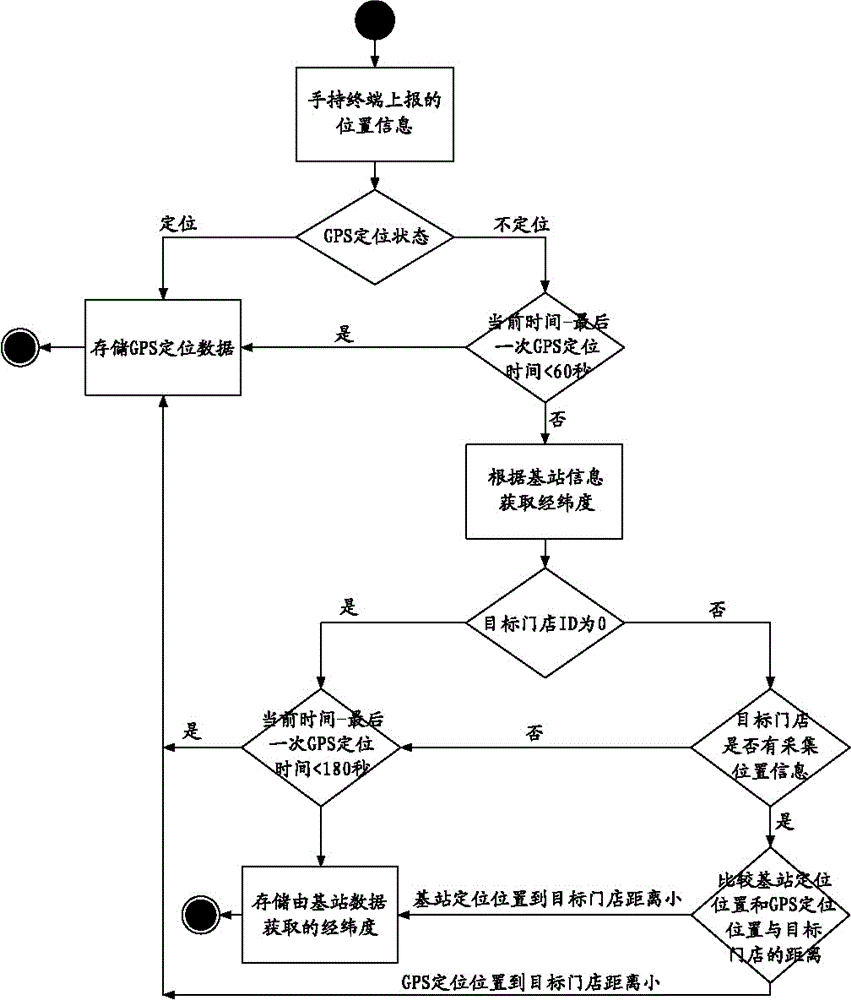
Owner:XIAMEN YAXON NETWORKS CO LTD
Infrared induction positioning equipment for dismounting elevator
ActiveCN224135530UComprehensive infrared scanPrecise disassembly workStands/trestlesElectric machinerySlide plate
The utility model discloses an infrared induction positioning device for dismounting an elevator, and relates to the technical field of elevator dismounting, the infrared induction positioning device comprises a bottom plate and a plurality of vertical rods, the plurality of vertical rods are fixedly arranged at four corners of the upper surface of the bottom plate, and a movable frame is arranged above the bottom plate; limiting blocks are fixedly arranged at the positions, corresponding to the vertical rods, of the side wall of the movable frame, the limiting blocks are movably connected with the corresponding vertical rods in a sleeving mode, a threaded rod is rotationally arranged in the movable frame, the rod wall of the threaded rod is in threaded sleeving connection with a sliding plate, and a first motor is fixedly arranged on the outer wall of one side of the movable frame; the output end of the first motor is fixedly connected with one end of a threaded rod, and a plurality of infrared sensors are sequentially and fixedly installed on the lower side of the sliding plate from front to back. According to the automatic dismounting device, comprehensive infrared scanning can be carried out on the elevator, so that the automatic dismounting device can carry out precise dismounting work, the height of the infrared sensor can be adjusted, and the elevators of different specifications can be conveniently positioned.


Owner:HUBEI PINDA CONSTRUCTION ENGINEERING IND CO LTD
Recorder sharing auxiliary positioning method and system
The invention provides a recorder sharing auxiliary positioning method and system. The recorder sharing auxiliary positioning system comprises a recorder positioning module, a recorder satellite processing module, a server time-sharing sharing module and a recorder sharing auxiliary positioning module. The output end of the recorder positioning module is connected with the input end of the recorder satellite processing module, the output end of the recorder satellite processing module is connected with the input end of the server time-sharing module, and the output end of the server time-sharing module is connected with the input end of the recorder sharing auxiliary positioning module. The output end of the recorder sharing auxiliary positioning module is connected with the input end of the recorder positioning module; in the absence of a satellite ground station and the Internet, the recorder can perform auxiliary positioning by sharing the geographic position and the detection time of the Beidou satellite in a time-sharing manner, so that the positioning speed and the positioning efficiency of the recorder are improved, the recorder can be normally used by a user in a closed network environment, and the positioning accuracy is relatively high.

Owner:DEEP BLUE PERCEPTION (HANGZHOU) IOT TECH CO LTD
A GPS drift data filtering method, system and terminal
ActiveCN107884793BPositioning data is accurateSatellite radio beaconingWireless communicationTelecommunicationsEngineering
The invention discloses a GPS drift data filtering method, system and terminal, comprising: acquiring GPS positioning data, searching for WIFI hotspots and saving them; and correcting the positioning data according to the changes of the acquired WIFI hotspots. Using WIFI hotspots to correct GPS data, when the user carries a GPS filter terminal and moves in an environment with WIFI signals, it can filter short-distance GPS drift data to make the positioning data more accurate.
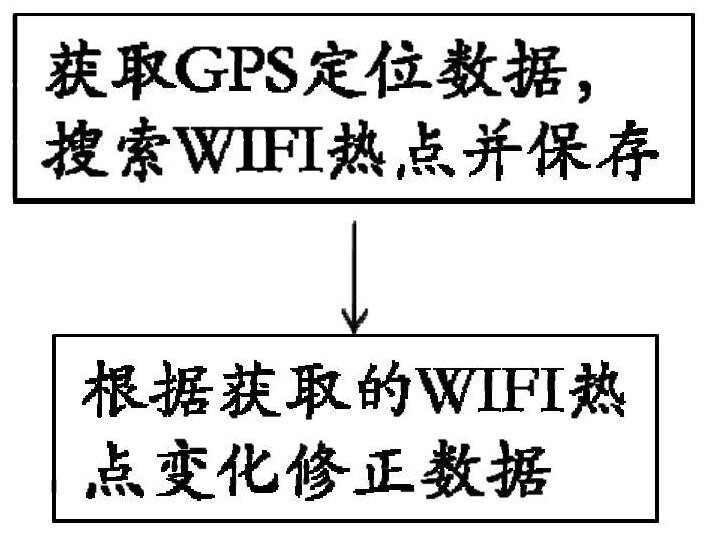
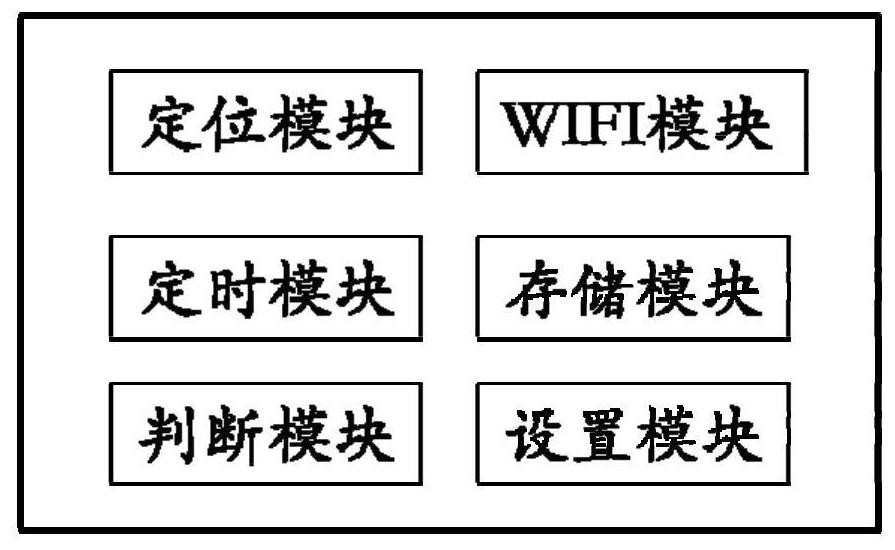
Owner:XIAMEN YAXON NETWORKS CO LTD
Gyroscope-based determination method of GPS capture time interval during curve driving
ActiveCN107505639BEnsure driving safetyPositioning data is accurateSatellite radio beaconingGyroscopeAngular velocity
The present invention relates to a gyroscope-based GPS packet capture time interval determination method during a curve driving process. The method comprises the steps of obtaining the parameters of a gyroscope and a change matrix to calculate the total angular velocity at a vehicle initial position during the curve driving; restarting the gyroscope to eliminate the error of the obtained gyroscope parameter data, and obtaining the horizontal direction angular velocity at the initial position again; carrying out the horizontal correction on the turning angular velocity at the vehicle initial position during the curve driving by the operation of a spatial geometric coordinate system; obtaining the critical value of the sharp turning angular velocity at vehicle turning by a real vehicle experiment and the normal distribution calculation, and gathering and comparing the angular velocity data; analyzing the degree of error between the GPS packet capture time interval and sharp turning data to obtain the packet capture time interval of a GPS minimum error on different angular velocity conditions. The method of the present invention can remind the users to decelerate timely during the driving process, guarantees the curve driving safety, at the same time, enables a mobile phone APP to obtain the positioning data more accurately.
Owner:小花网络科技(深圳)有限公司
Remote vehicle detection and alarming device
ActiveCN102129758BPositioning data is accurateRealize real-time remote electrical and electronic fault alarmAnti-theft devicesAlarmsComputer moduleVehicle detection
Owner:哈尔滨海铭科技有限公司
Method for locating unmanned aerial vehicle in diversion culvert based on single-line laser
ActiveCN111854756APositioning data is accurateHigh precisionInternal combustion piston enginesNavigational calculation instrumentsPoint cloudUncrewed vehicle
The invention relates to a method for locating an unmanned aerial vehicle in a diversion culvert based on single-line laser. The method comprises the steps: step 1, constructing a point cloud model ofa diversion culvert; step 2, acquiring height information and original attitude data acquired by an unmanned aerial vehicle; step 3, obtaining unmanned aerial vehicle position data through a positionobtaining sub-method, and obtaining optimized unmanned aerial vehicle attitude data through an attitude obtaining sub-method; and step 4, obtaining accurate positioning of the unmanned aerial vehiclein the diversion culvert according to the position data of the unmanned aerial vehicle and the optimized attitude data. Compared with the prior art, the method has the advantages of high positioningprecision, high processing speed and the like.
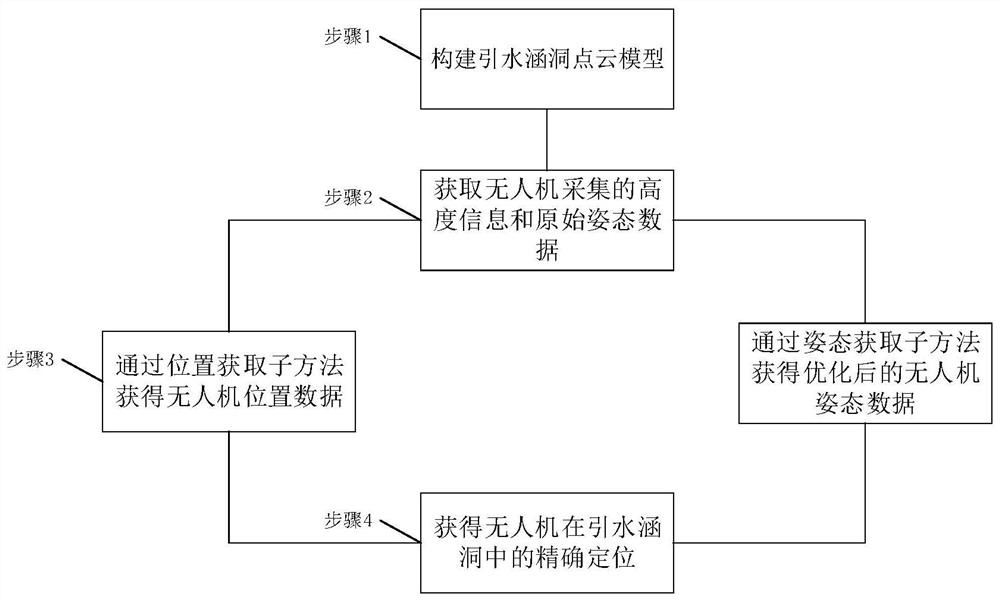
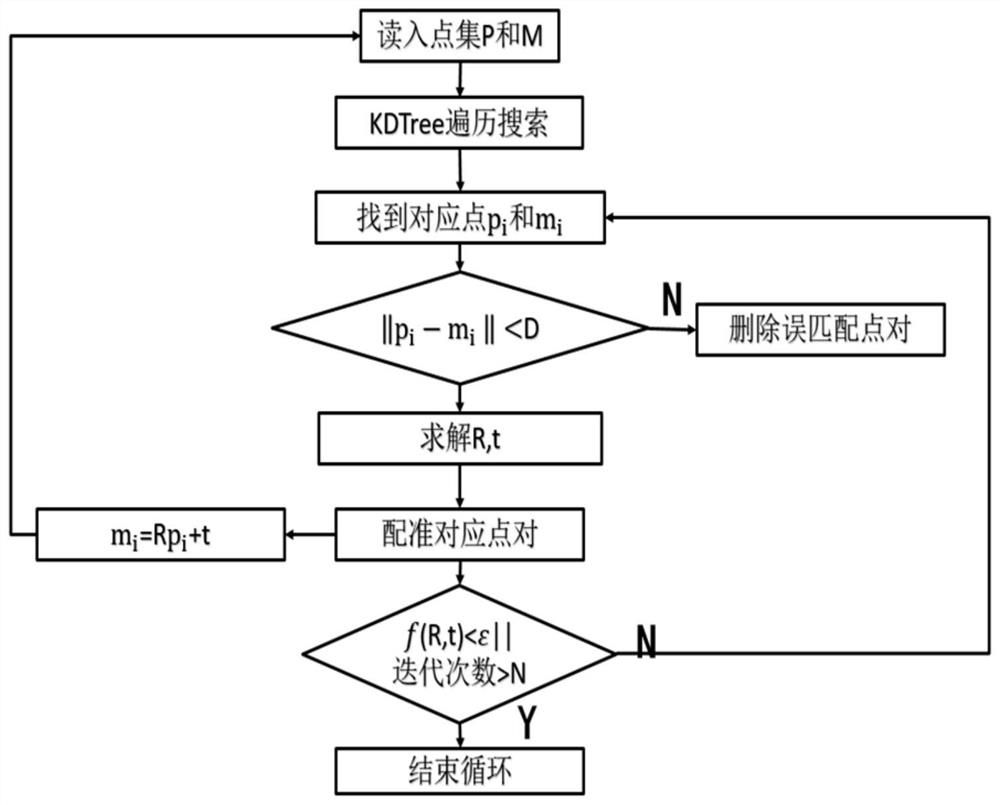
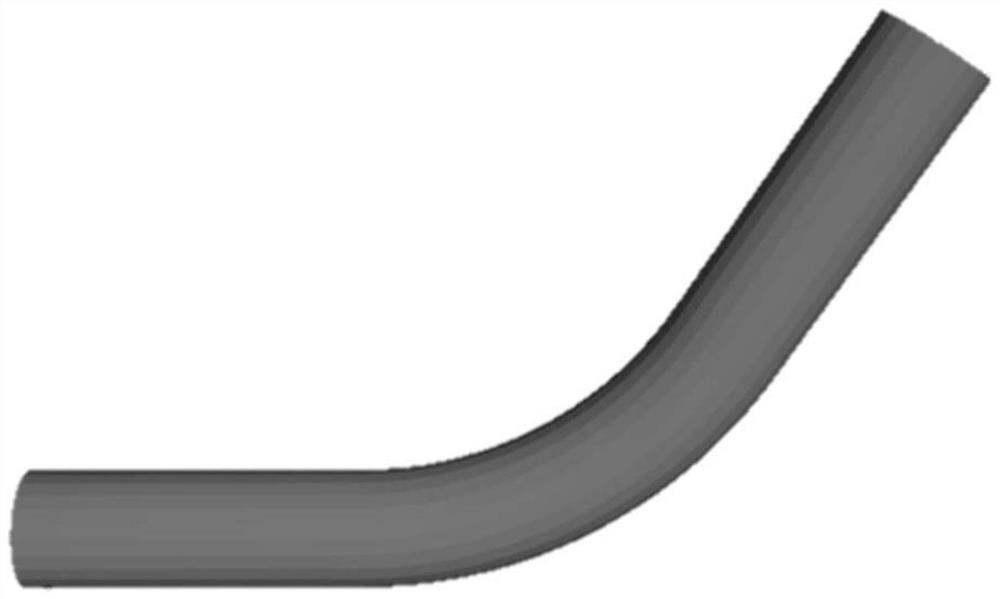
Owner:TONGJI UNIV
Curved surface correction information processing method and device based on laser locator
InactiveCN102654826ARelaxation of rectification conditionsLow costBuilt-on/built-in screen projectorsDigital output to display deviceInformation processingProjection image
The invention relates to curved surface correction information processing method and device based on a laser locator, wherein the method comprises the following steps: 1) firstly, adjusting projection hardware equipment to locate a projector and projection screen equipment at set positions and directions, and performing step 2); 2) correcting a projection image through a main control machine, adjusting the edge fusion part to enable the image to be tangent to the screen, and performing step 3); 3) locating the specific information of the projection image through the laser locator; 4) judging whether to receive a projection equipment adjusting command through the main control machine, if so, performing step 5); and if not, performing step 7); and 5) adjusting the projection equipment and performing step 6), wherein the device comprises the main control machine, the projector, the laser locator and a projection screen. Compared with the prior art, the method and device disclosed by the invention have the advantages of low cost, convenience in operation and accurate locating data.
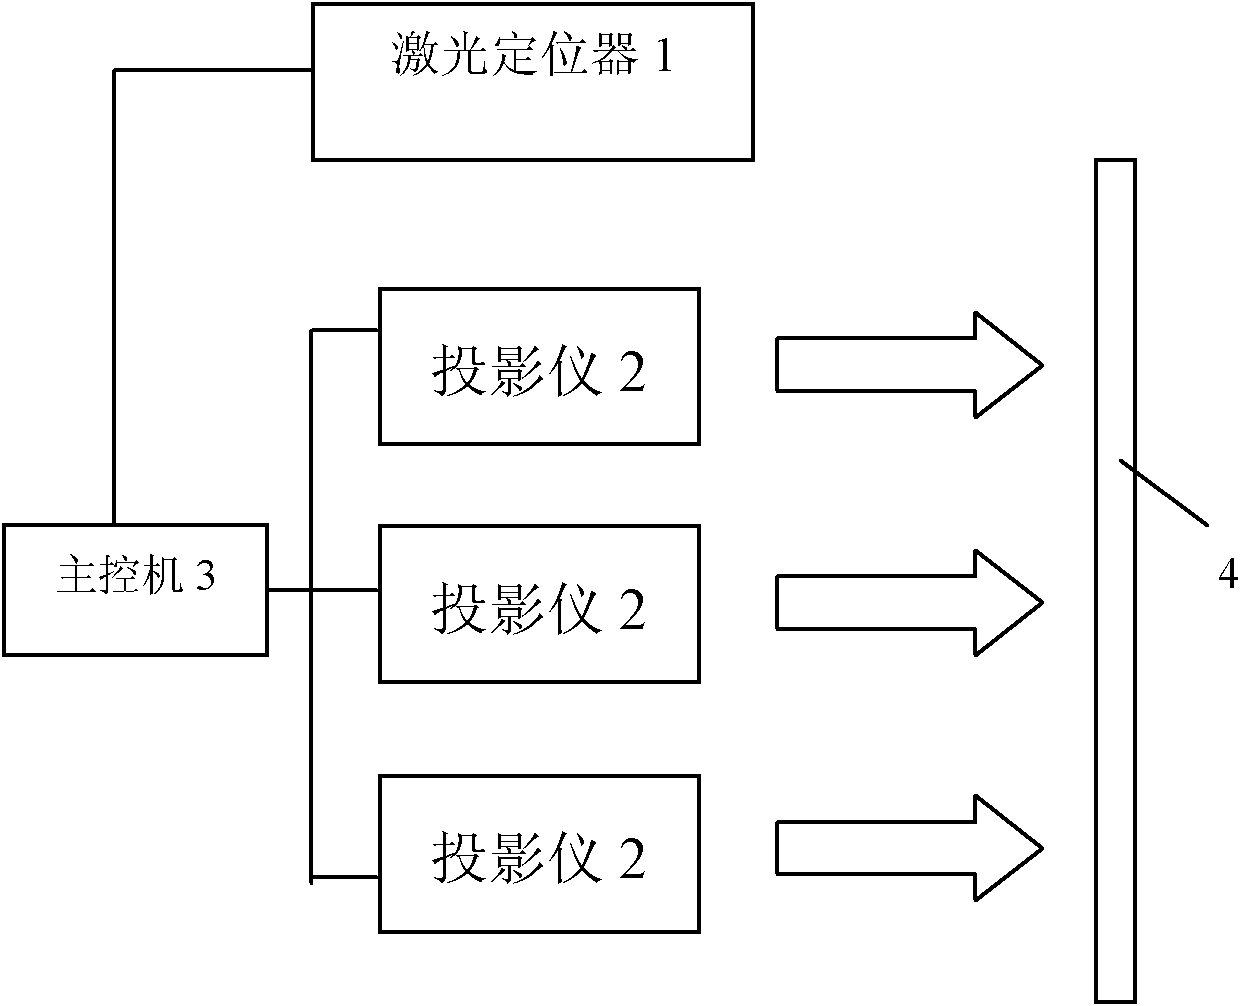
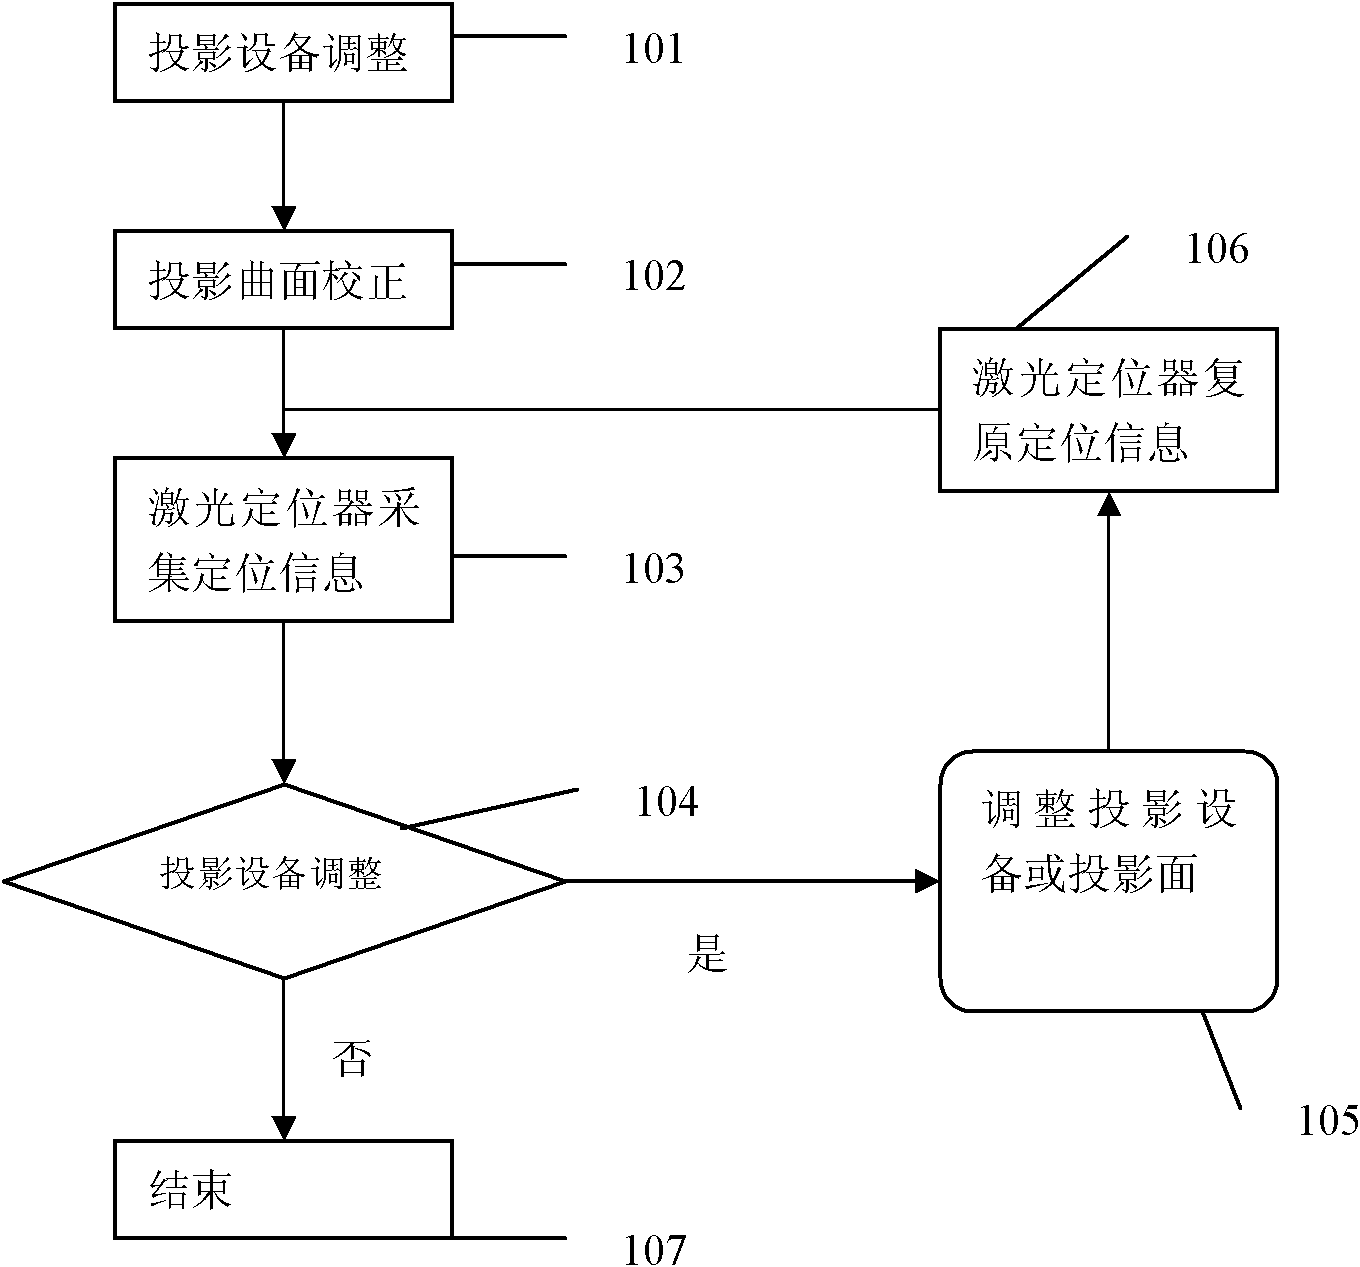
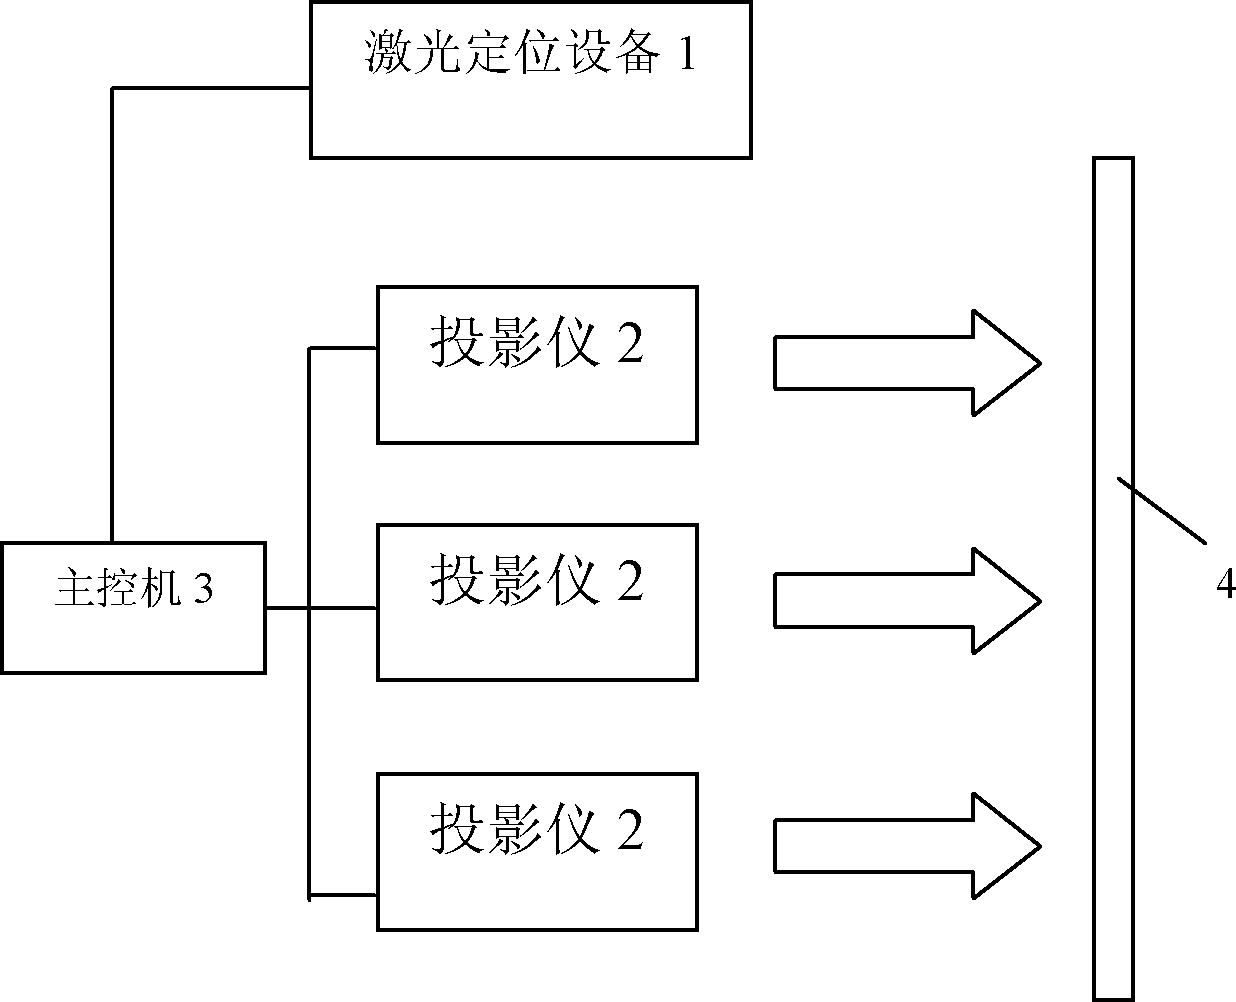
Owner:SHANGHAI HUABO INFORMATION SERVICE
Article tracking control method and device based on mirror cabinet and readable medium
PendingCN114780048ASolve the problem that it is not easy to find itemsEasy to displayWash-standsPosition fixationComputer graphics (images)Engineering
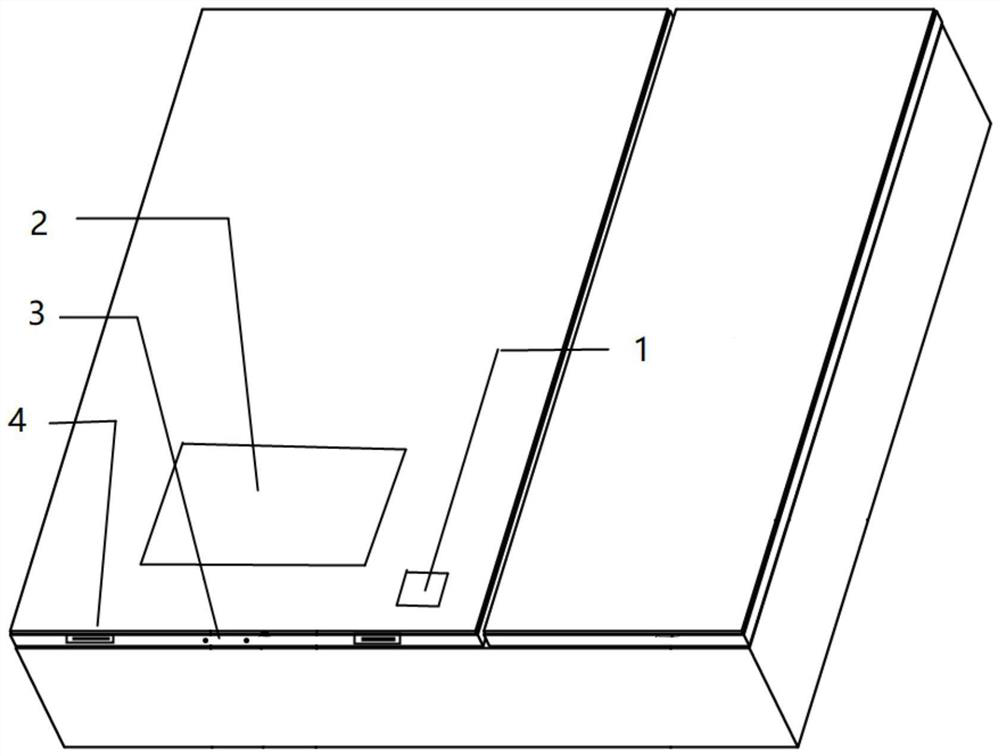
The invention discloses an article tracking control method and device based on a mirror cabinet and a readable medium, and the method comprises the steps: obtaining positioning point UWB data of different positioning points in a designated region, and building a positioning relation between the positioning point UWB data of each positioning point in the designated region and the corresponding positioning point; establishing an association relationship between the unique identification code of the tracker installed on the to-be-tracked article and the information of the to-be-tracked article; and obtaining UWB positioning data and Bluetooth positioning data corresponding to the unique identification code of the tracker, and determining positioning information of the to-be-tracked article according to the UWB positioning data, the positioning relationship and the association relationship in response to determining that a first difference value between the Bluetooth positioning data and the UWB positioning data is within a first threshold range, the positioning information comprises to-be-tracked article information and a position in a specified area; and controlling a display screen on the mirror cabinet to display the positioning information of the to-be-tracked article. Therefore, tracking and accurate positioning of the articles can be realized, a good visualization effect is provided, and the articles are more convenient to find in combination with alarm control of the tracker.
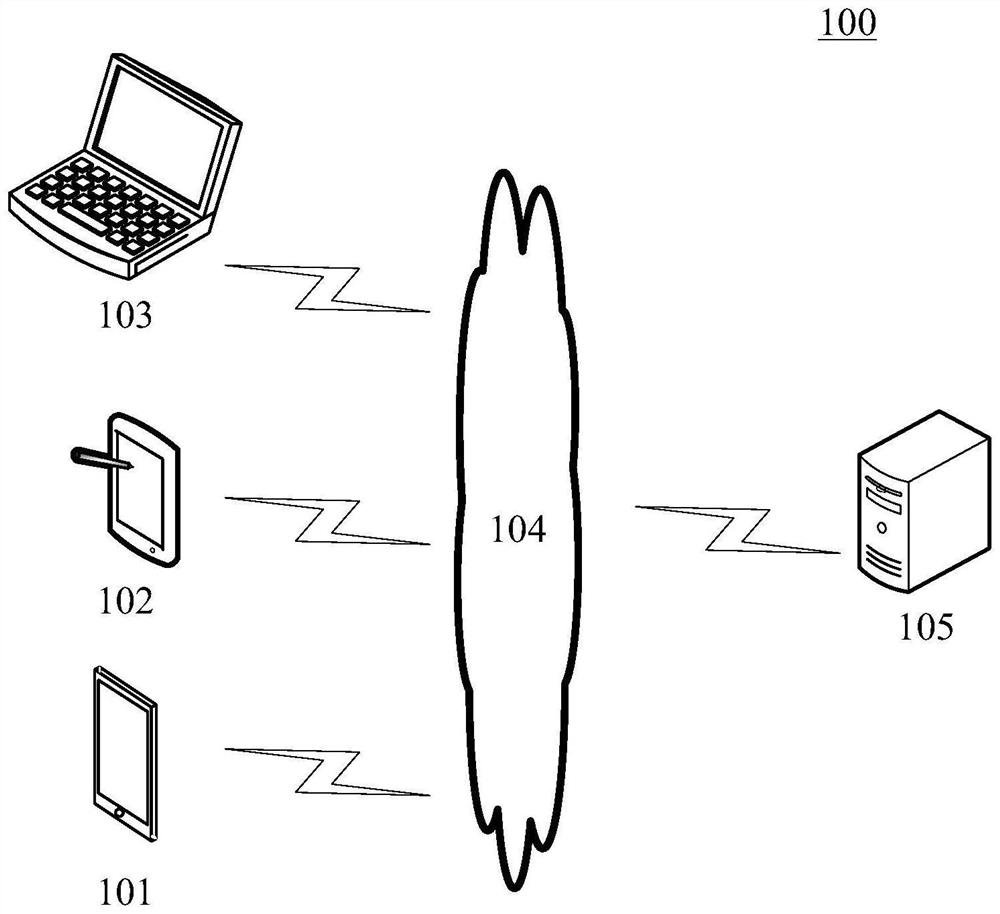
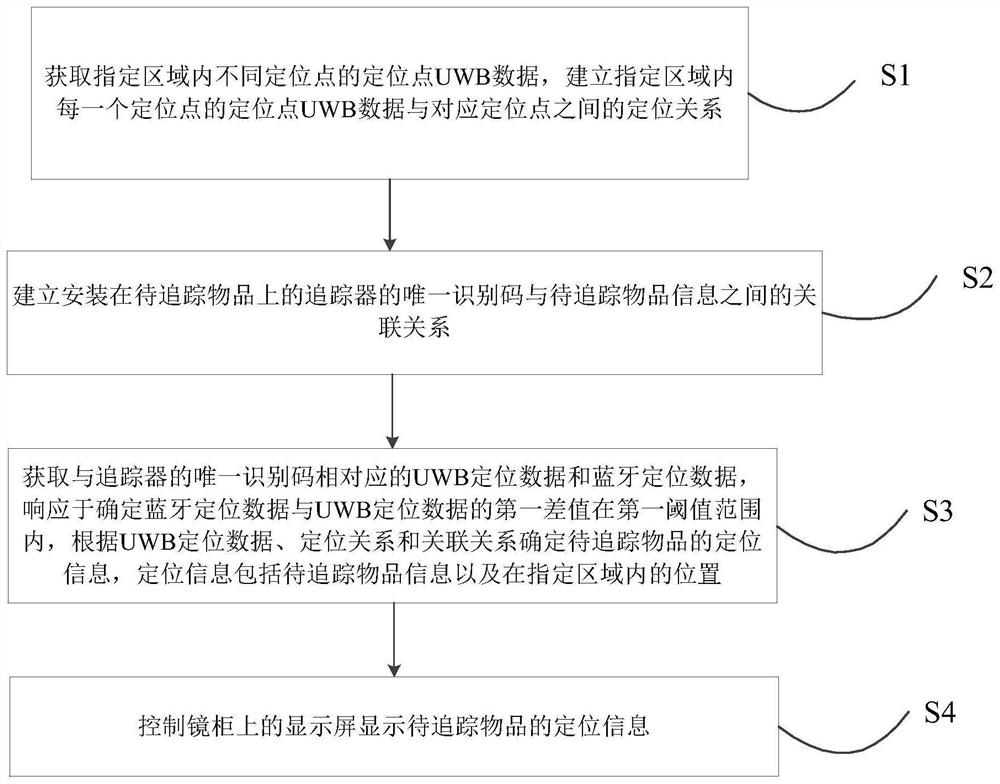
Owner:JOMOO KITCHEN & BATHROOM
A positioning system and positioning method based on multi-sensor data fusion
ActiveCN110231027BAccurately obtain all-round mobile dataHigh precisionNavigation by speed/acceleration measurementsVertical planeGyroscope
Owner:XI AN JIAOTONG UNIV
Warehousing and stacking goods positioning method and device
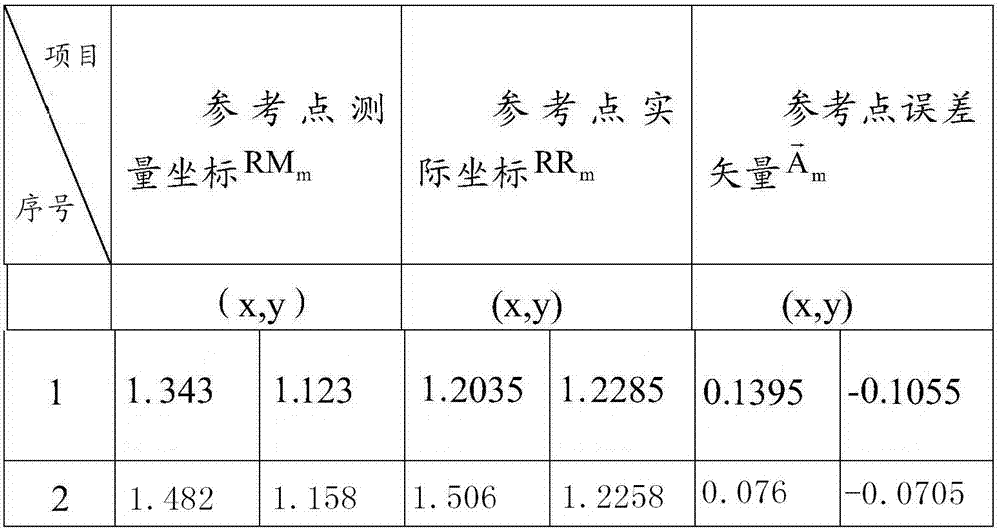
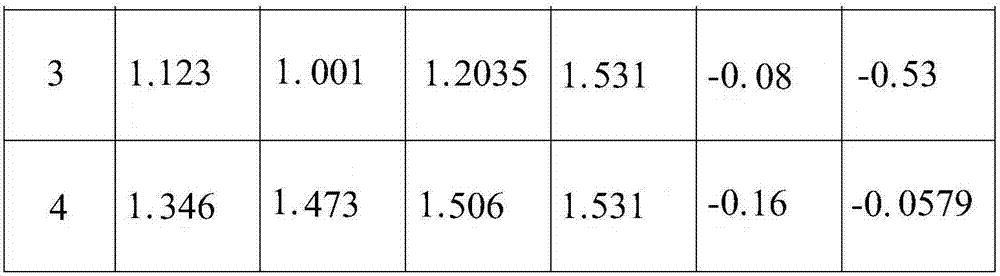
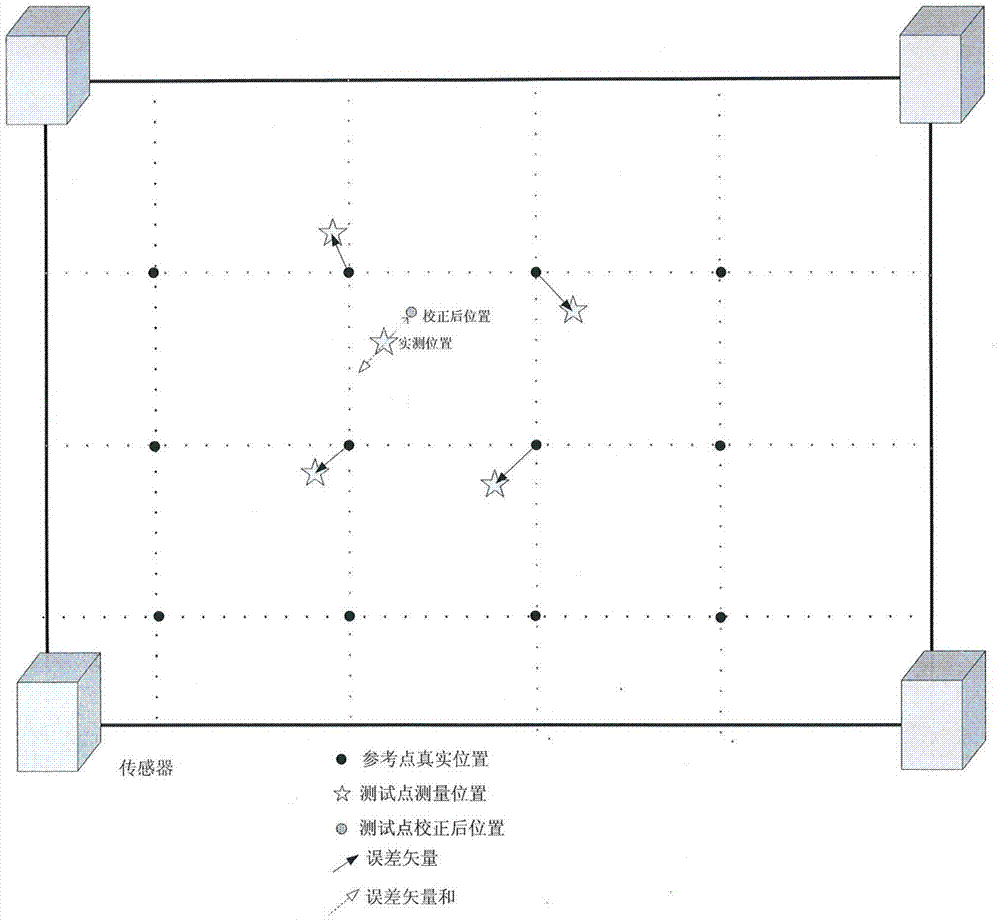
Owner:BEIJING INSTITUTE OF PETROCHEMICAL TECHNOLOGY
An underwater sensor and a positioning system
ActiveCN109885279ACalculation speedReduce work energy consumptionDigital data processing detailsParallel computingComputer module
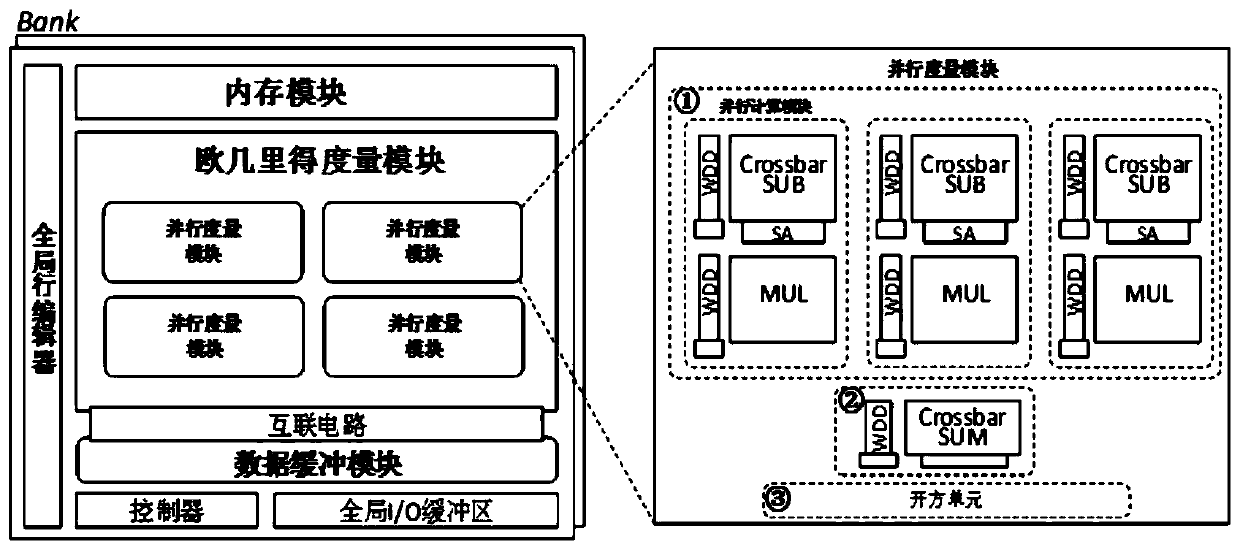
The invention provides an underwater sensor and a positioning system. The underwater sensor comprises a ReRAM and a controller, and the controller is connected with the ReRAM; wherein the ReRAM comprises a memory module and an Euclidean measurement module; the memory module is used for caching input data; the Euclidean measurement module comprises a plurality of parallel measurement modules, and each parallel measurement module comprises an addition calculation module, an extraction calculation module and a plurality of parallel calculation modules; the parallel computing module comprises a first subtraction array and a first multiplication array; the parallel computing module is used for performing parallel computing on each addend in the Euclidean metric formula; and the addition calculation module is used for completing a summation process of operation results of all units of the parallel calculation module and taking the results as input data of the evolution calculation module.
Owner:无锡航征科技有限公司
Synchronous localization and mapping method and device in dynamic environment
PendingCN119295689Aaccurate extractionavoid interferenceImage analysis3D modellingComputer graphics (images)Thresholding
The invention provides a synchronous positioning and mapping method and device in a dynamic environment, and belongs to the technical field of robot mapping and localization, and the method comprises the steps: carrying out the target detection of a to-be-detected image, and obtaining a detection frame and the type of a target object; judging the state of the target object according to the corresponding relation between the object category and the state in a preset rule; dividing each pixel in the to-be-detected image into a neighborhood window with a preset size, calculating a local threshold value of each pixel point, and extracting feature points of the to-be-detected image based on the local threshold values; traversing the feature points, and removing the feature points in the detection frame where the target object in the motion state is located; performing camera pose estimation according to the target feature point to obtain camera pose data; and constructing a map based on the camera pose data. According to the method, the feature points of the to-be-detected image in the dynamic environment can be accurately identified, and the dynamic feature points in the feature points are removed, so that more accurate positioning and map construction are realized.

Owner:CHANGAN UNIV
Multi-sensor positioning method, algorithm and device for salt pan raking machine
ActiveCN119291750APositioning data is accurateReduce labor costsNavigation by speed/acceleration measurementsSatellite radio beaconingData synchronizationAlgorithm
The invention belongs to the technical field of salt pan outdoor positioning, and particularly relates to a multi-sensor positioning method, algorithm and device for a salt pan raking machine. The multi-sensor positioning method for the salt pan raking machine comprises the following steps: S1, acquiring data information by using a GPS (Global Positioning System) and an IMU (Inertial Measurement Unit) inertial navigation sensor, and synchronizing the data time between the two sensors according to the timestamp of the data; s2, determining a conversion relation matrix between the two sensors according to the relation between the relative positions and the relative poses of the two sensors, and synchronizing the data of the two sensors to the same coordinate system; s3, fusing the synchronized data through an improved extended Kalman filtering strategy to obtain position data of the live ballast machine; and S4, feeding back the positioned position data to a live ballast machine console. According to the method, GPS and IMU data information are fused to obtain more accurate and more stable position information of the live ballast machine, and the algorithm provides position information of the live ballast machine for autonomous work of the live ballast machine.

Owner:TIANJIN CHANGLU HAIJING GRP CO LTD