
Patents
Literature
51 results about "Meteorite craters" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Method and apparatus for three-dimensional compositional mapping of heterogeneous materials
InactiveUS6873419B2Rapid and accurate three-dimensional compositionalRapid and accurate depth profileAnalysis by thermal excitationUsing optical meansCoherence lengthLaser ablation
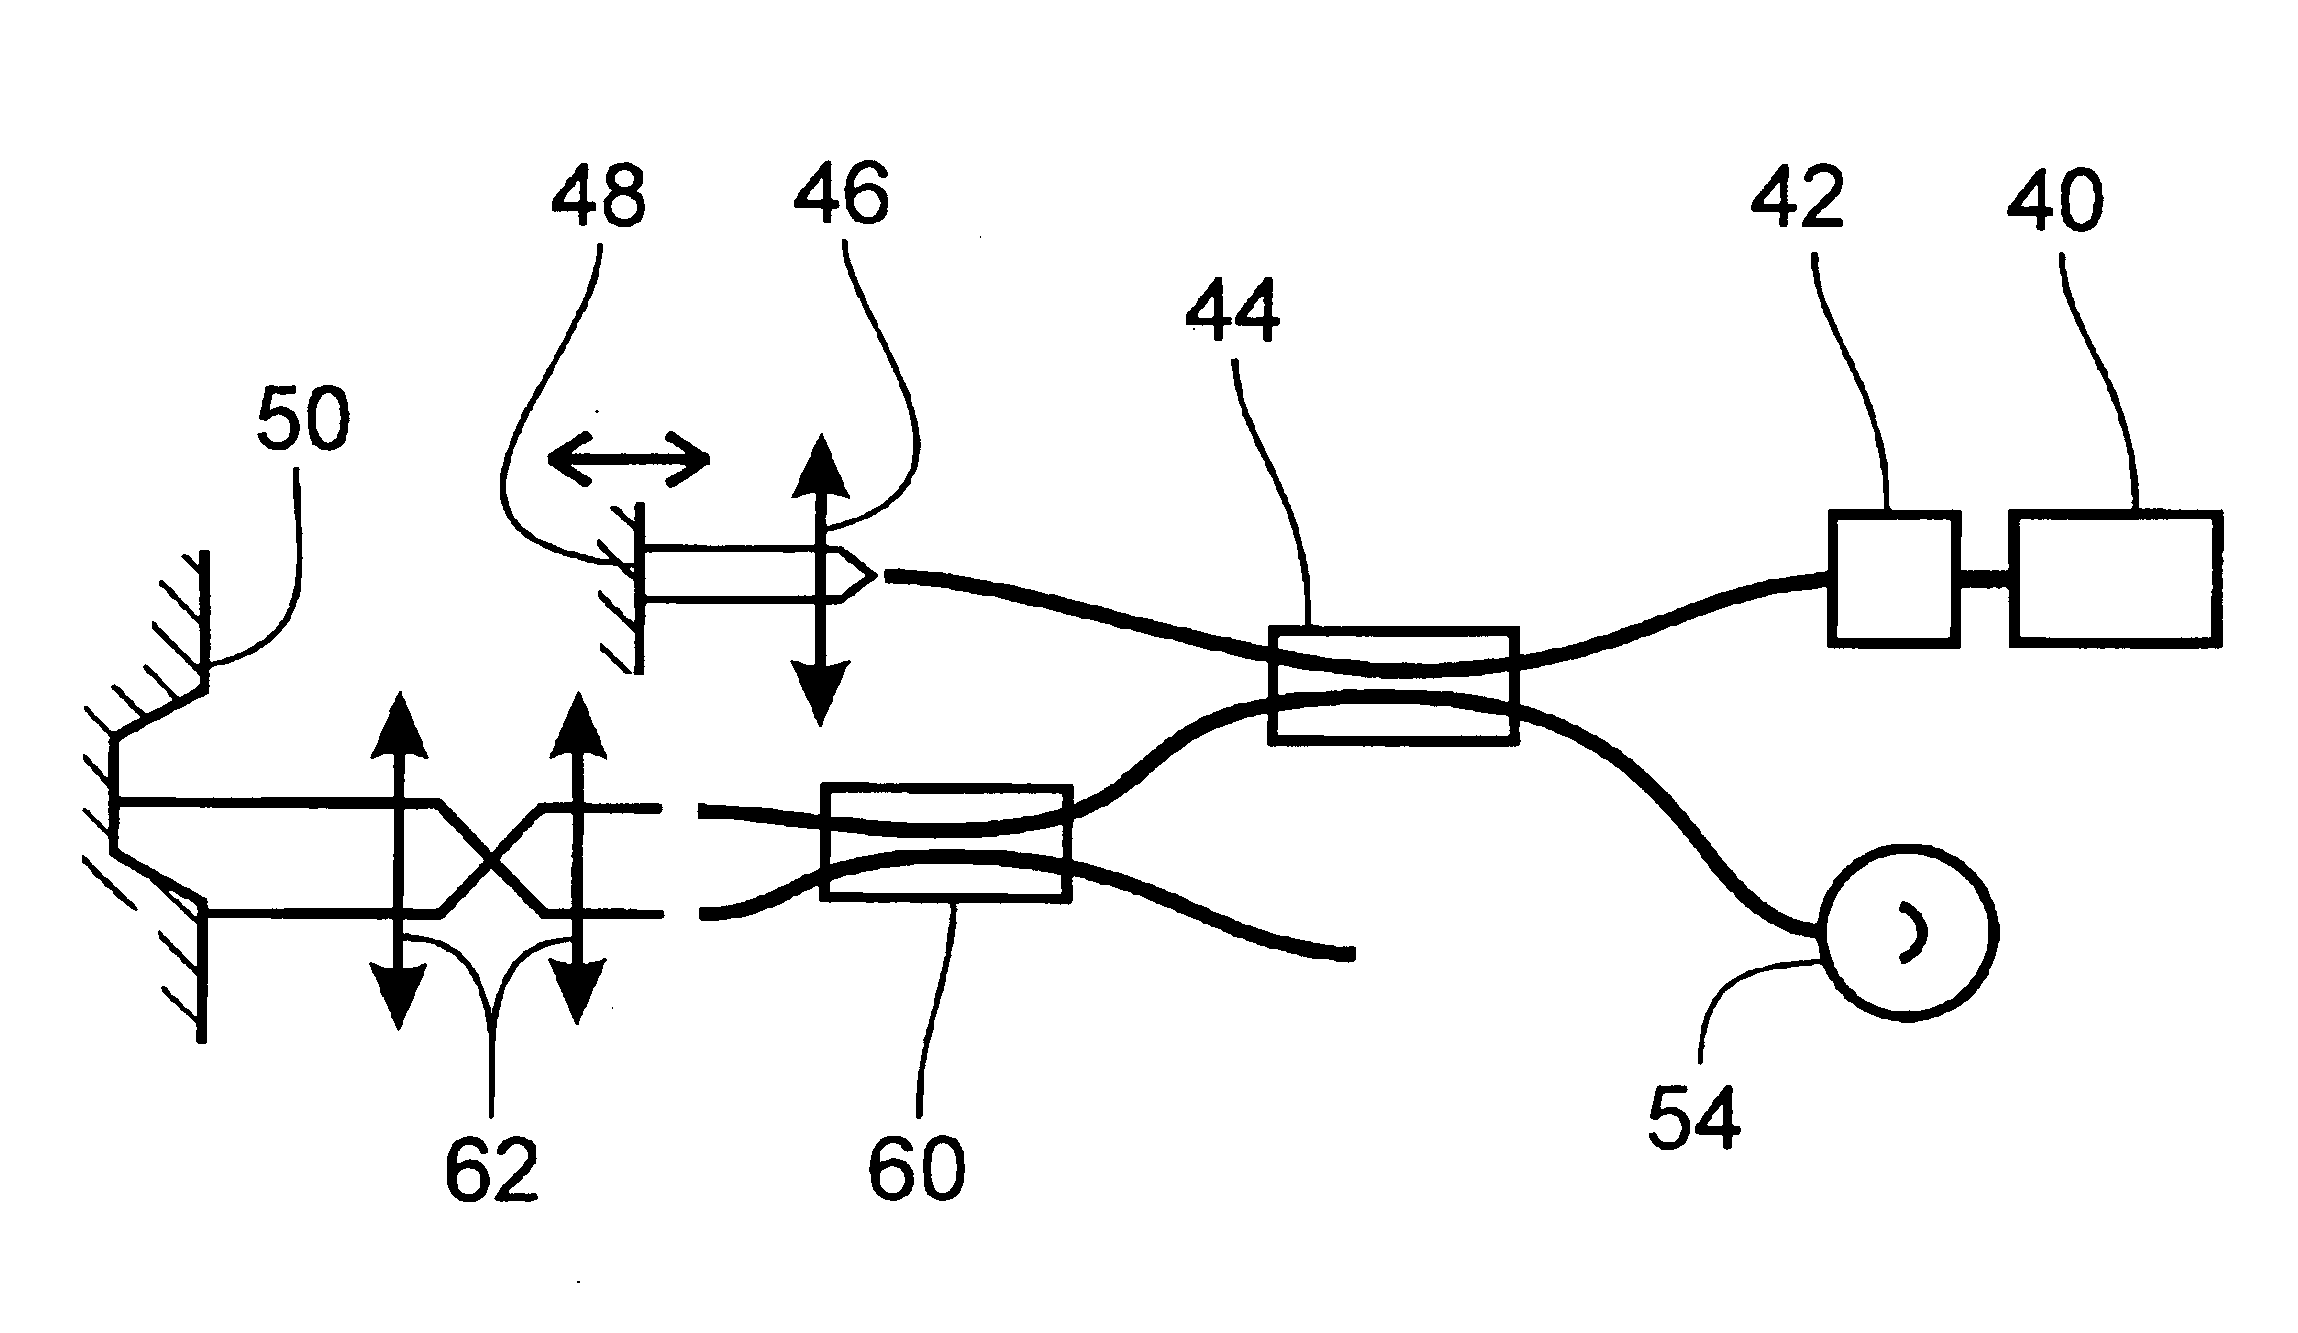
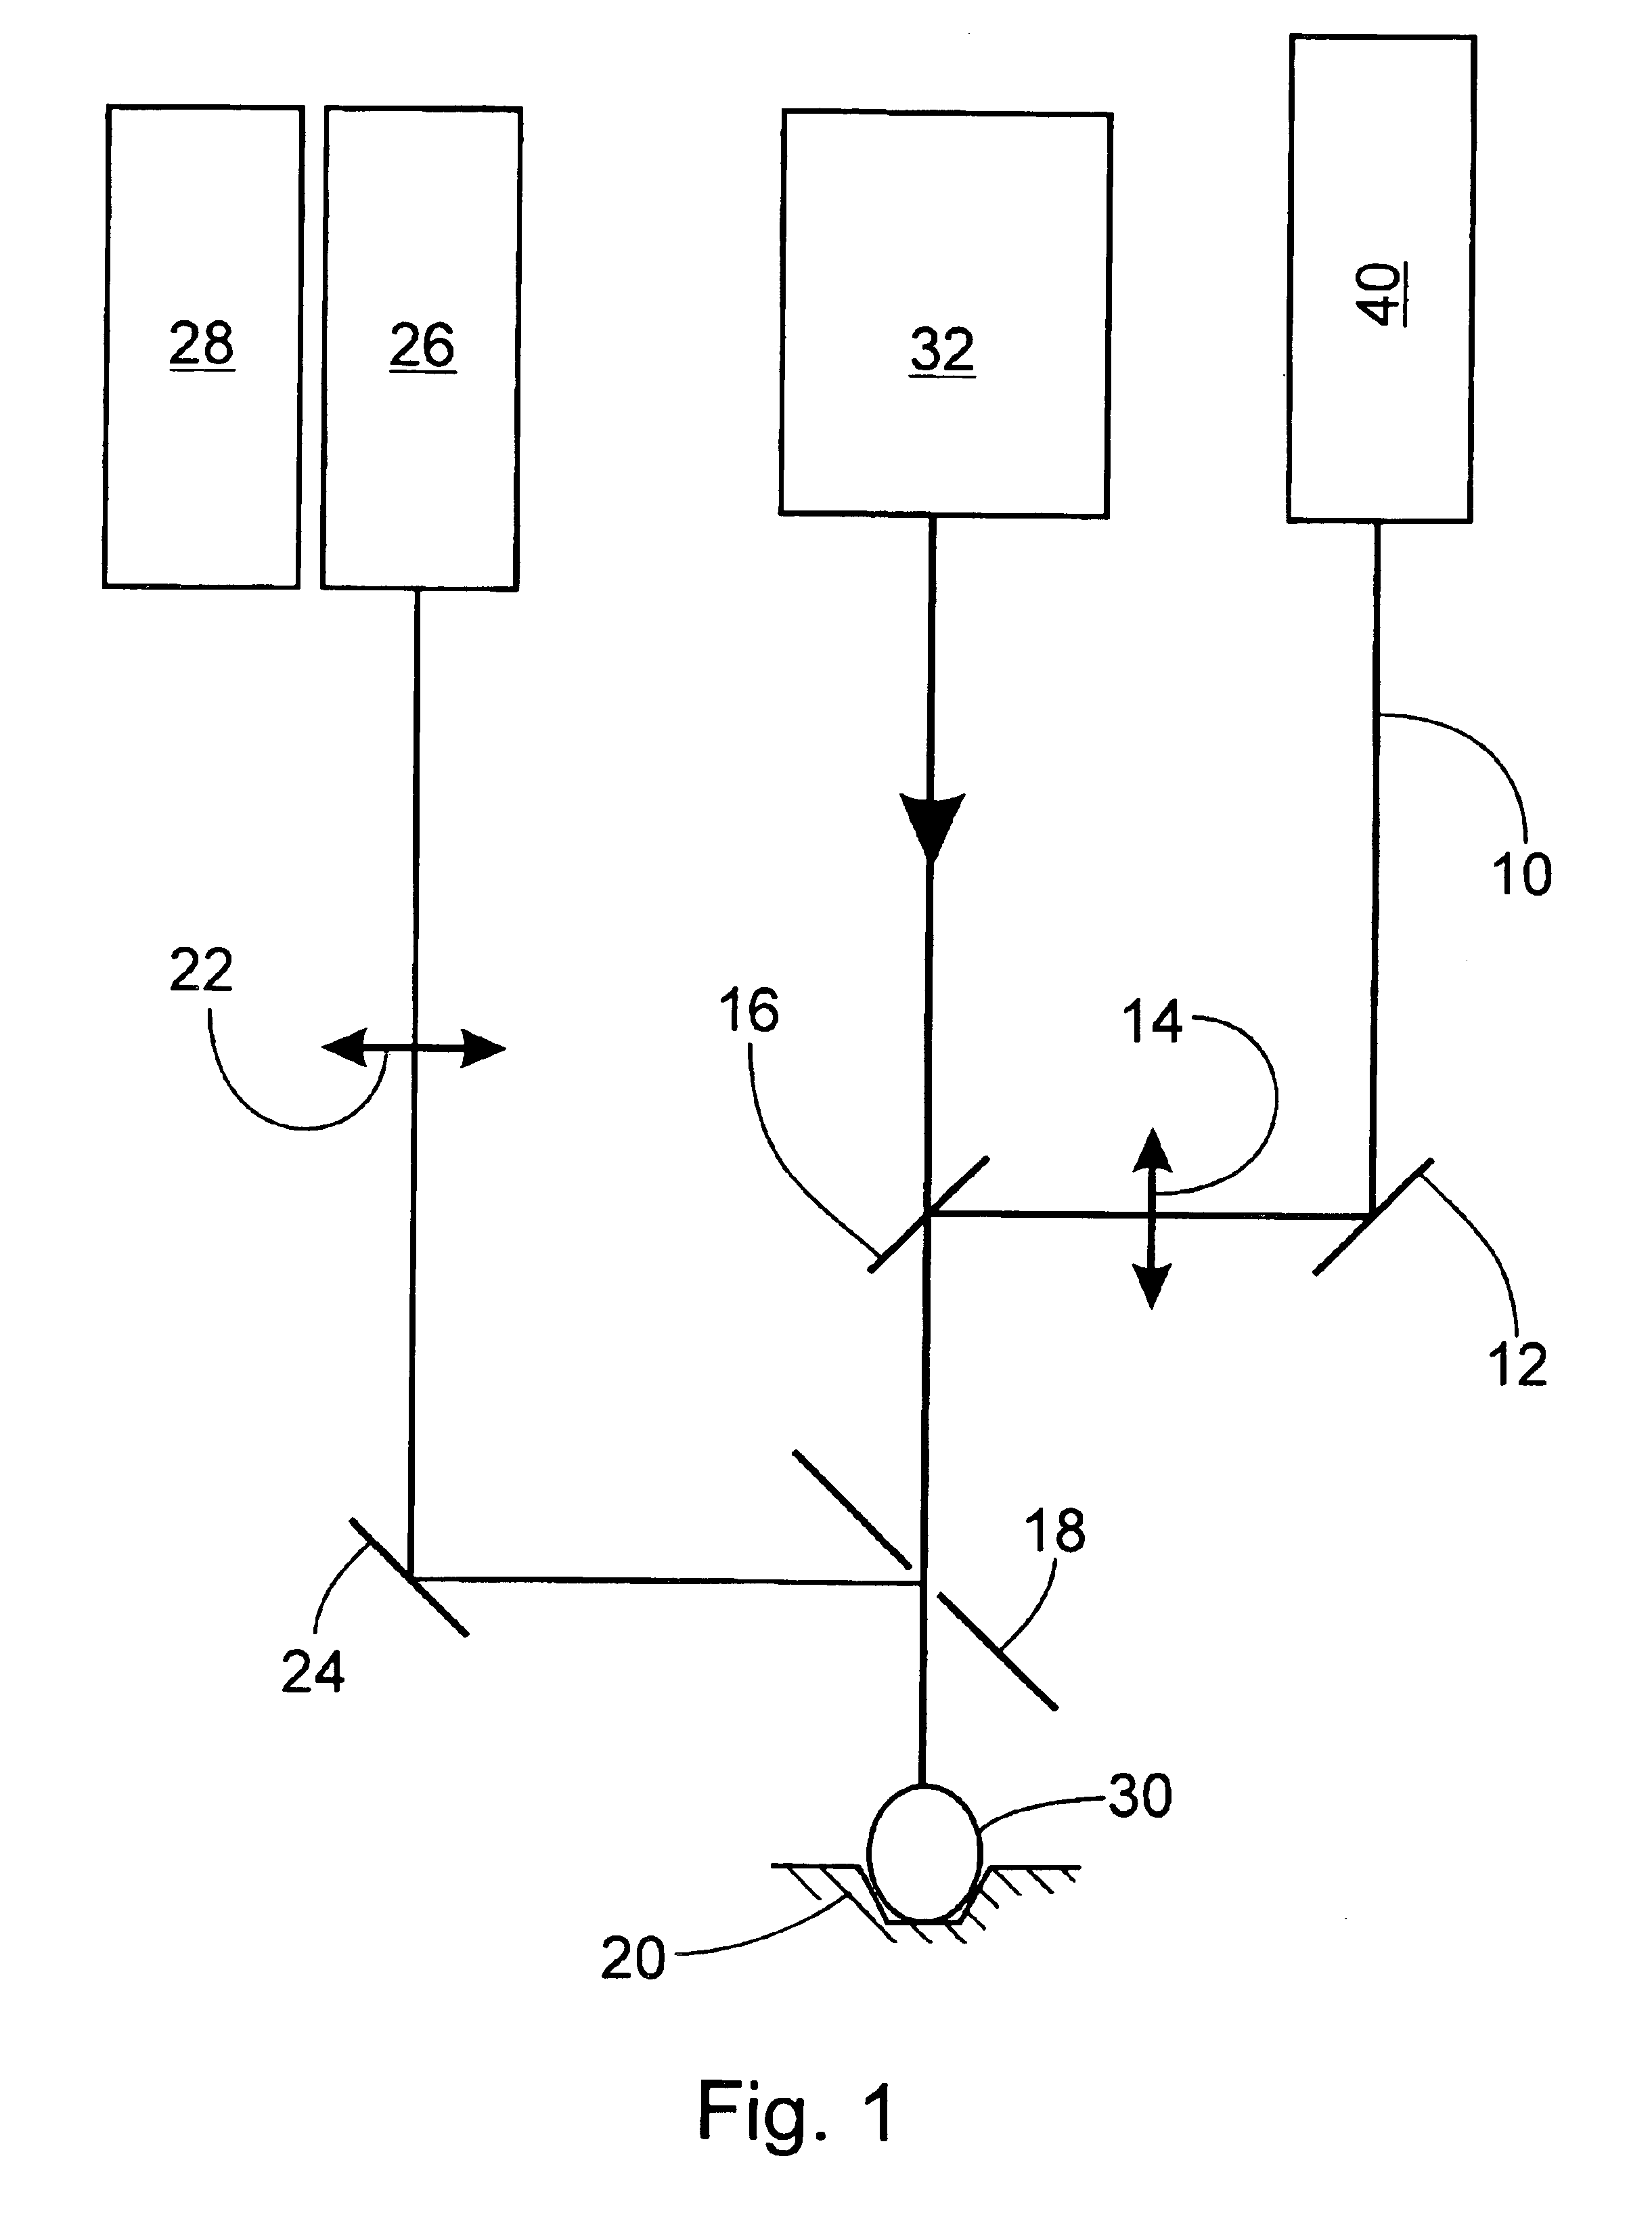
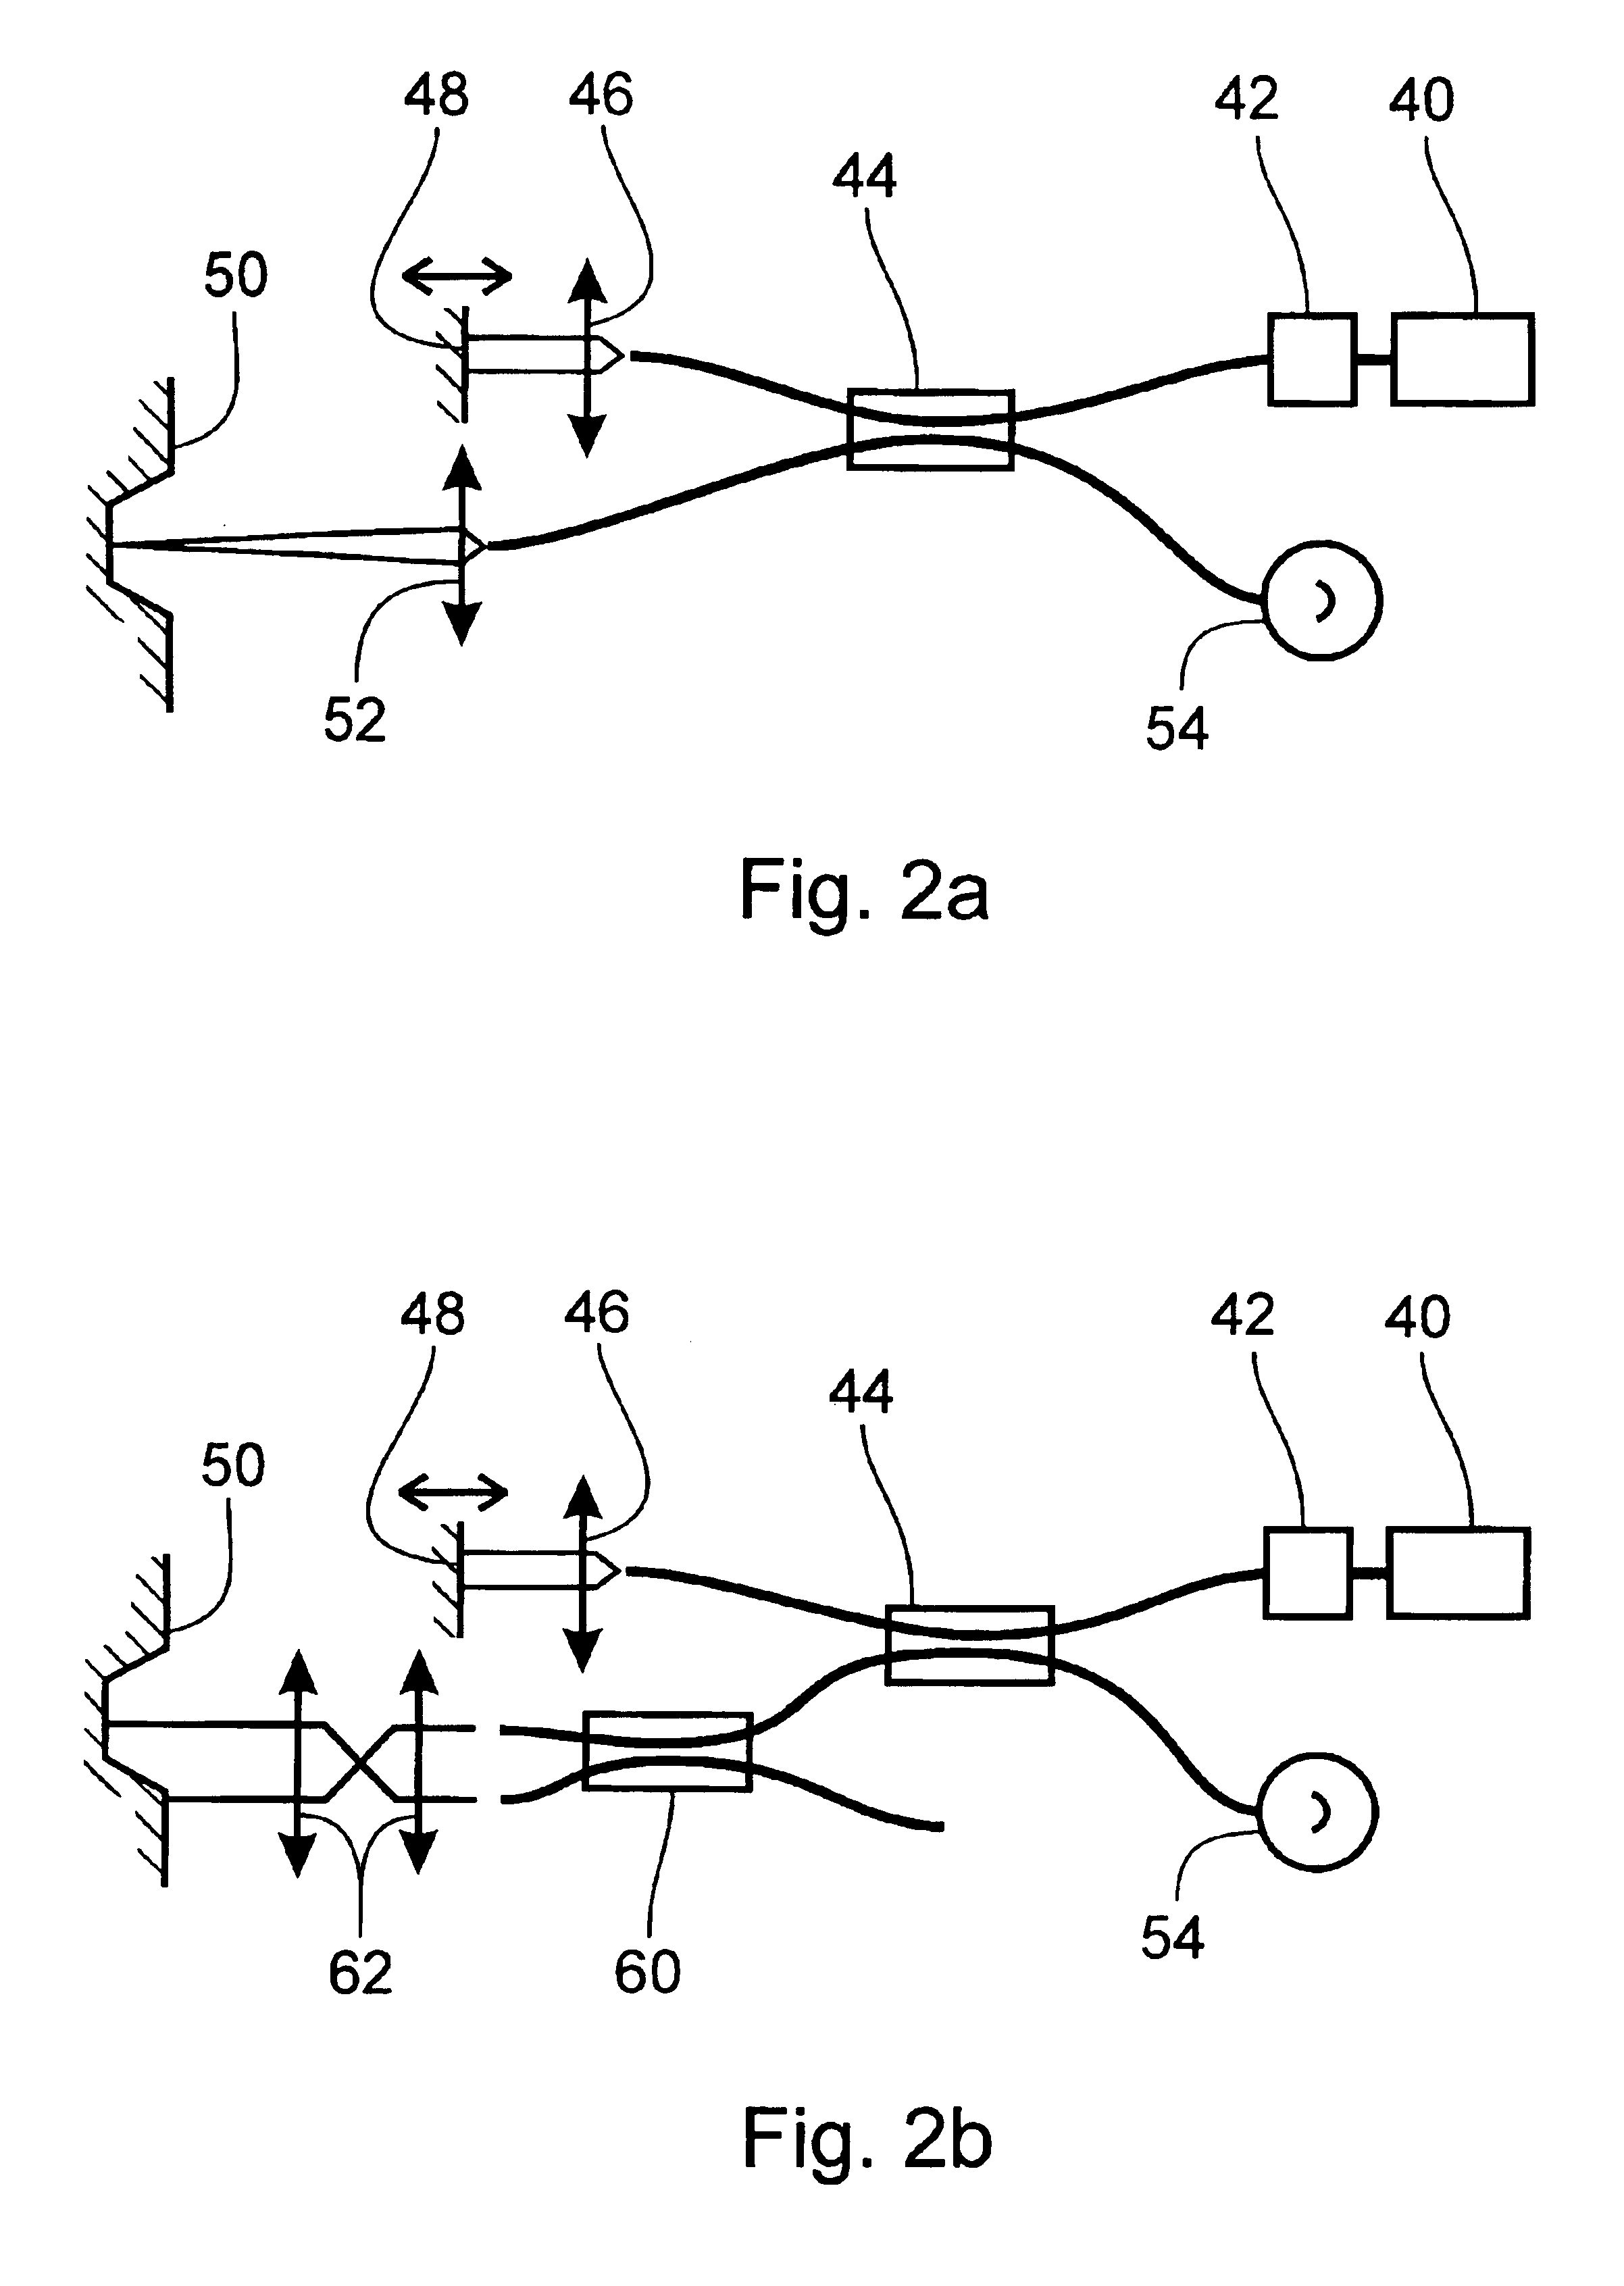
Laser ablation combined with spectrometric analysis is a good tool for determining the composition of heterogeneous materials. By measuring the depth of an ablation crater at a target of a heterogeneous material, it is possible to generate a compositional profile as a function of the depth. It is also possible to generate a 3 dimensional profile by depth profiling of a plurality of craters. The depth measurement is conducted in situ and in real time so that the evolution of composition as a function of the depth can be measured. An interferometric technique with a short coherence length light is one of the preferred embodiments for measuring the depth in situ and in real time.
Owner:NAT RES COUNCIL OF CANADA
Meteorite crater matching method based on area ratio
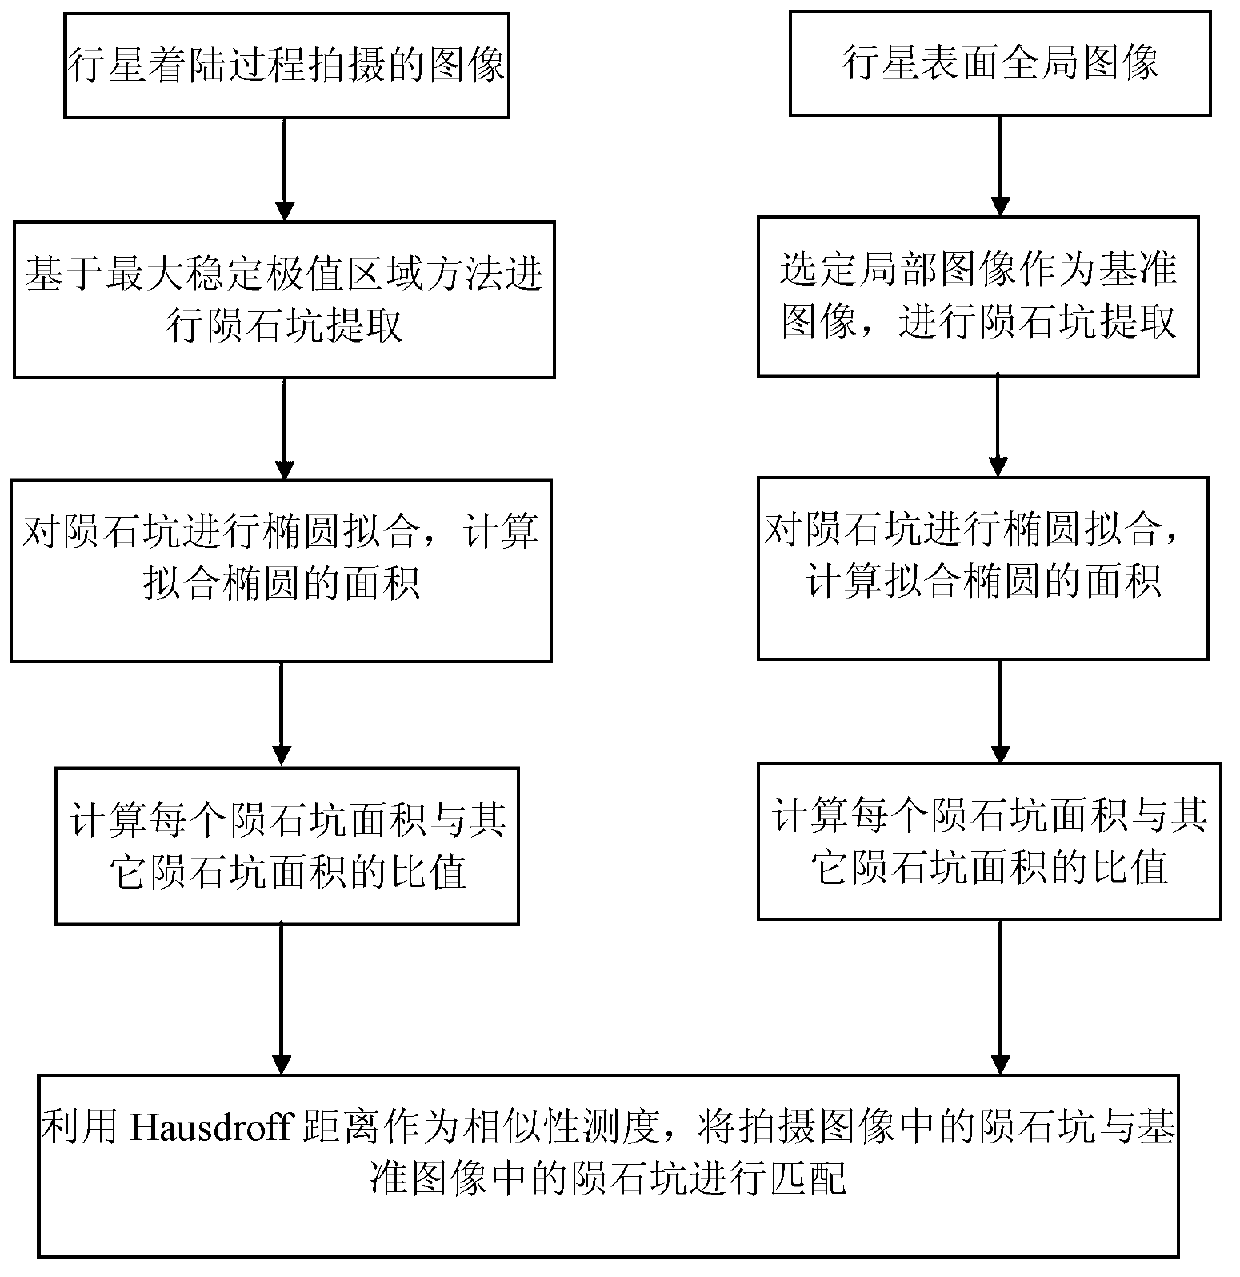
The invention relates to a meteorite crater matching method based on area ratio, which solves the problems of relatively large rotation of images, mistake matching, mismatching and the like under the conditions of scaling and deformation existing in the existing meteorite crater matching method. The meteorite crater matching method based on area ratio relates to the technical field of image processing, comprising the following steps: selecting out local images in a global image on the surface of a planet as a reference image; then carrying out extraction of meteorite craters on an image shot in landing process based on maximally stable extremal region method; carrying out ellipse fitting on the extracted meteorite craters in the shot image, and calculating the area of fit ellipse; respectively calculating the area ratio between different meteorite craters in the shot image and the area ratio between different meteorite craters in the reference image; and finally utilizing Hausdroff distance as similarity measurement, and matching the meteorite craters detected in the shot image with the meteorite craters in the reference image. The method can efficiently prevent the disadvantages of conventional matching methods, and is an ideal method for carrying out meteorite crater matching in landing process.
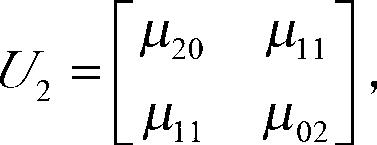
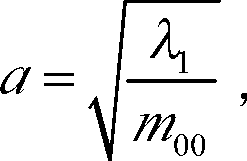
Owner:HARBIN INST OF TECH
Road sign observation information evaluation optimization method of small irregular celestial body surface
ActiveCN110095123AImprove navigation accuracyHigh precisionNavigational calculation instrumentsInstruments for comonautical navigationCamera imageImaging processing
The invention, which belongs to the autonomous navigation, discloses a road sign observation information evaluation optimization method of a small irregular celestial body surface. The method comprises: on the basis of an image processing algorithm, detecting and extracting meteorite crater observation information of a small celestial body surface in a navigation camera image; carrying out ellipsefitting and meteorite crater center positioning on the detected and extracted meteorite crater and calculating an error uncertainty matrix R of the meteorite crater based on uncertainty propagation characteristics; according to a pixel coordinate and an image line coordinate of a navigation road sign observed in the navigation image, constructing an observation matrix H; and constructing an evaluation index function based on the R and H and selecting an optimal navigation road sign preferably with consideration of the observation error and position formation distribution of the navigation road sign, According to the selected optimal meteorite crater navigation road sign, a position attitude of a deep space detector is determined, so that the navigation accuracy of the position attitude ofthe deep space detector is improved.


Owner:BEIJING INSTITUTE OF TECHNOLOGYGY
Inertial navigation assisted meteorite crater coarse-to-fine detection method
ActiveCN111652896AAccurate and safe landingAvoid it happening againImage enhancementImage analysisComputational scienceFast Fourier transform
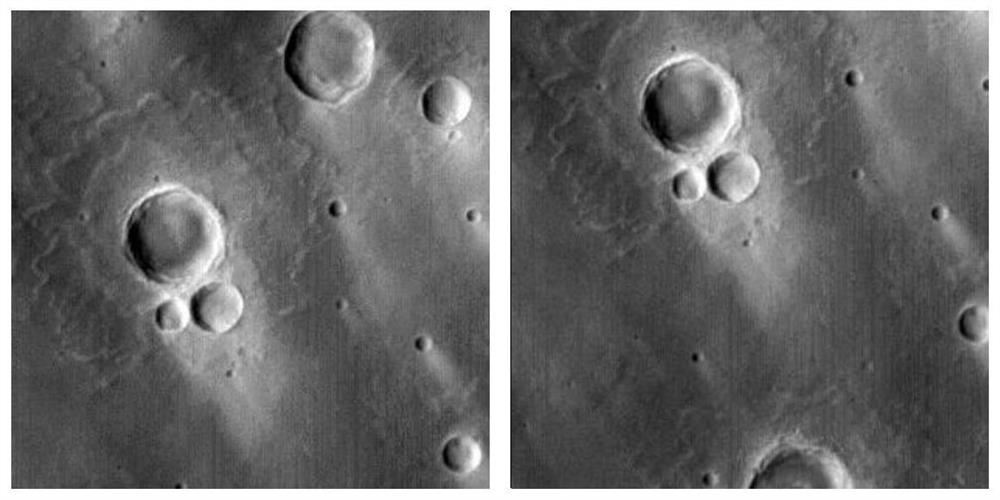
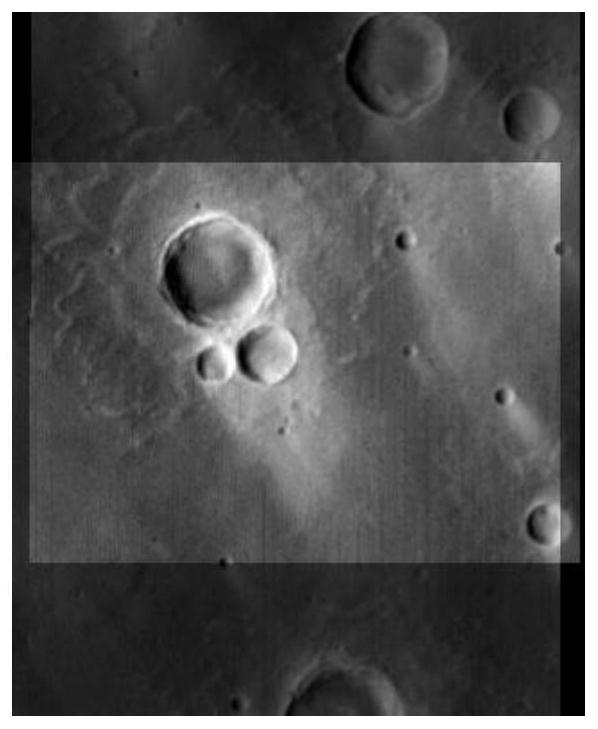
The invention discloses an inertial navigation assisted meteorite crater coarse-to-fine detection method, and belongs to the technical field of deep space exploration. The implementation method comprises the following steps: achieving meteorite crater image feature edge coarse extraction based on bright and dark region information; and searching the matching degree of the template and the image features by using fast Fourier transform so as to achieve coarse positioning of the area where the image features are located. Inertia measurement information is introduced to calculate the overlappingarea between images, the template shape is updated, and a search area is predicted. Fine detection of the single meteorite crater is achieved in the area where the single meteorite crater is located,so that topography information of a landing area is sensed, and accurate and safe landing of the lander is guaranteed. According to the method, the difficulties that the features cannot be detected and the recognition efficiency is low due to affine transformation and information redundancy among the sequence image features can be solved. The method is not only suitable for planet landing and small celestial body detection tasks, but also suitable for moon detection tasks.
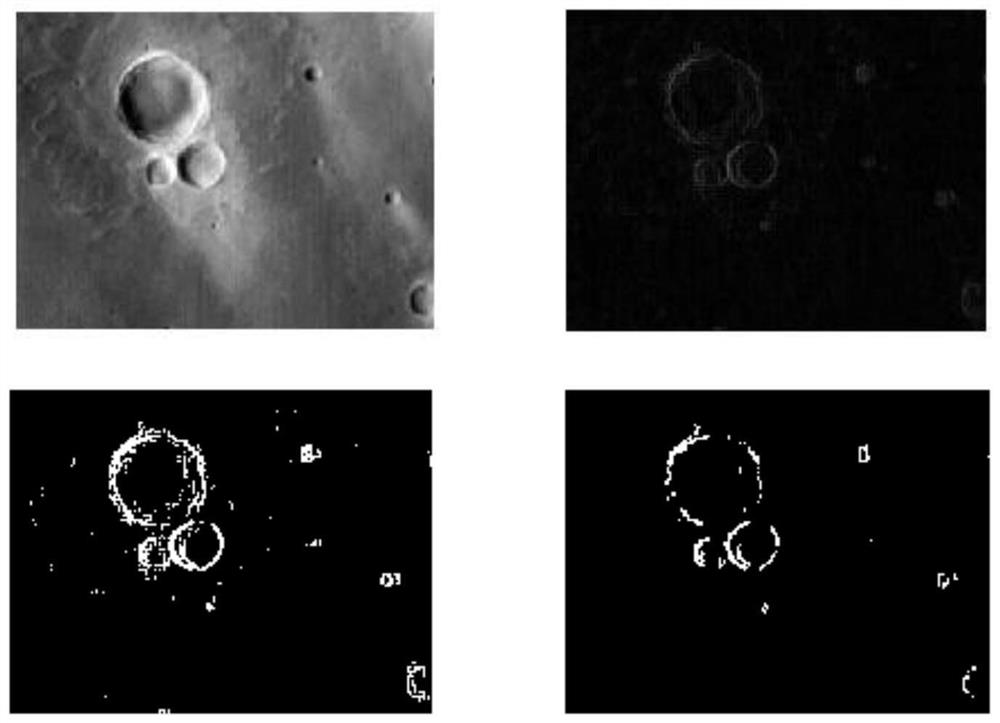
Owner:BEIJING INSTITUTE OF TECHNOLOGYGY
Detector landing point positioning method based on spiking neural network
PendingCN113375676AImprove integrityImprove accuracyInstruments for comonautical navigationNeural architecturesAlgorithmNetwork architecture
The invention discloses a detector landing point positioning method based on a pulse neural network. The method comprises the following steps: preprocessing meteorite crater DEM data on the surface of a star; training a training set data by adopting a U-Net network architecture based on an artificial neural network model ANN; converting the UNET of the artificial neural network model ANN into a UNET model of a pulse neural network model SNN; coding the image, and carrying out test set detection by adopting the UNET model based on SNN; and carrying out meteorite crater matching and positioning through a template matching algorithm, and constructing a terrain landmark library to realize positioning. The spiking neural network is applied to the field of deep space exploration for the first time, and positioning of the landing point of the detector is achieved by identifying the meteorite crater.


Owner:NANJING UNIV OF AERONAUTICS & ASTRONAUTICS
Lunar surface landing meteorite crater obstacle detection method, storage medium and electronic equipment
PendingCN114241296AIncrease diversityReduce target recognition error rateCharacter and pattern recognitionNeural architecturesData setMeteorite craters
The invention discloses a lunar surface landing meteorite crater obstacle detection method, a storage medium and electronic equipment, and the method comprises the steps: obtaining lunar remote sensing image data with a preset resolution, and making the lunar remote sensing image data into a meteorite crater data set; performing data enhancement processing on the image in the meteorite crater data set, and making a label for the meteorite crater data set after data enhancement processing; establishing a dense connection network model based on a YOLO-V4 backbone network structure; inputting the data set containing the meteorite crater label into the dense connection network model in a preset size, and setting preset training parameters to train the dense connection network model; and inputting a to-be-detected meteorite crater data set into the trained dense connection network model, so as to carry out target meteorite crater detection through the trained dense connection network model. According to the method, the meteorite crater obstacles with multi-scale changes can be autonomously identified, and avoidance of dangerous landing areas in the rough obstacle avoidance stage of lunar landing can be conveniently completed.


Owner:SHANGHAI AEROSPACE CONTROL TECH INST
Multi-purpose planetary exploration vehicle
ActiveCN110758772ASimple structureReduce volumeCosmonautic power supply systemsSteering linkagesMeteorite cratersEngineering
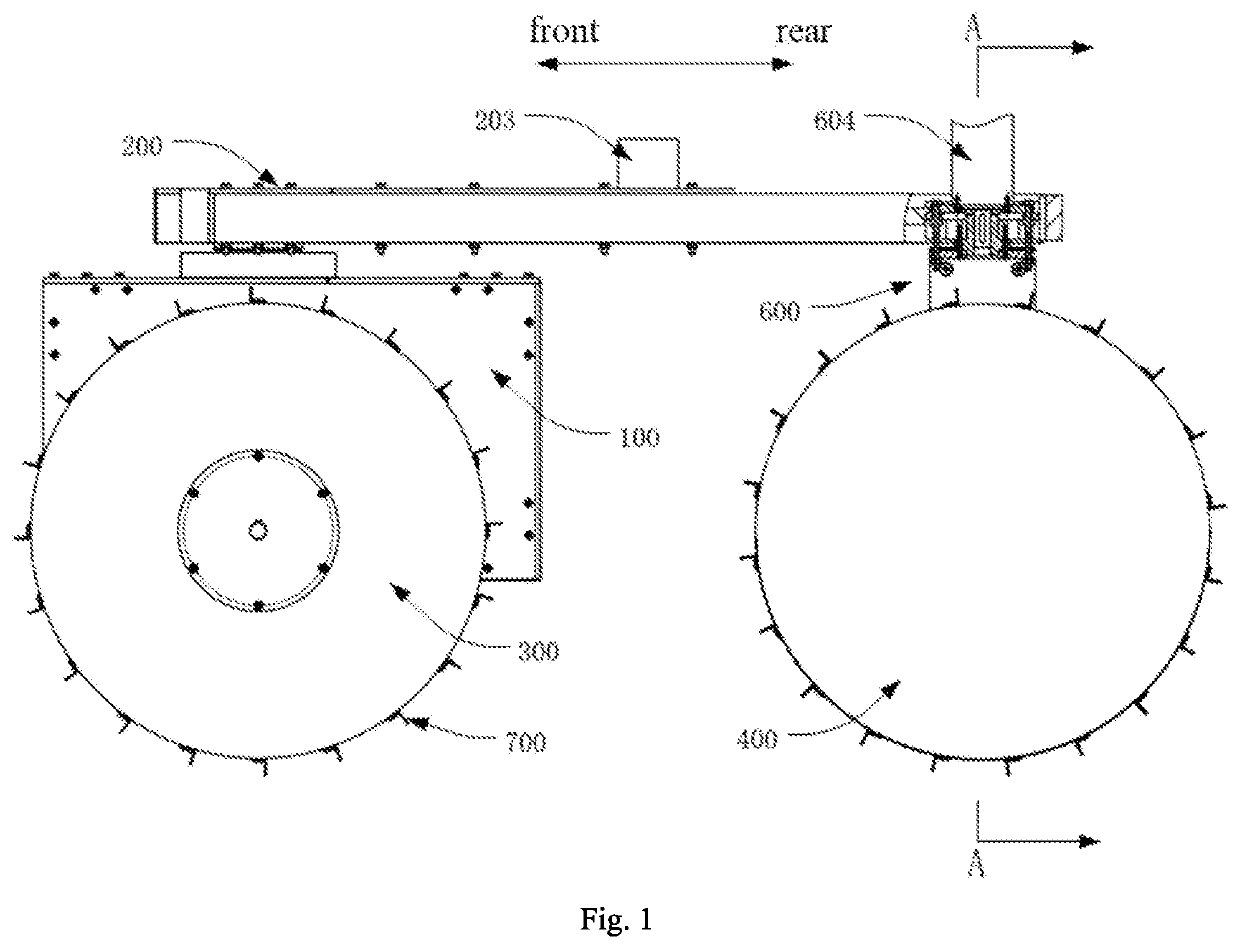
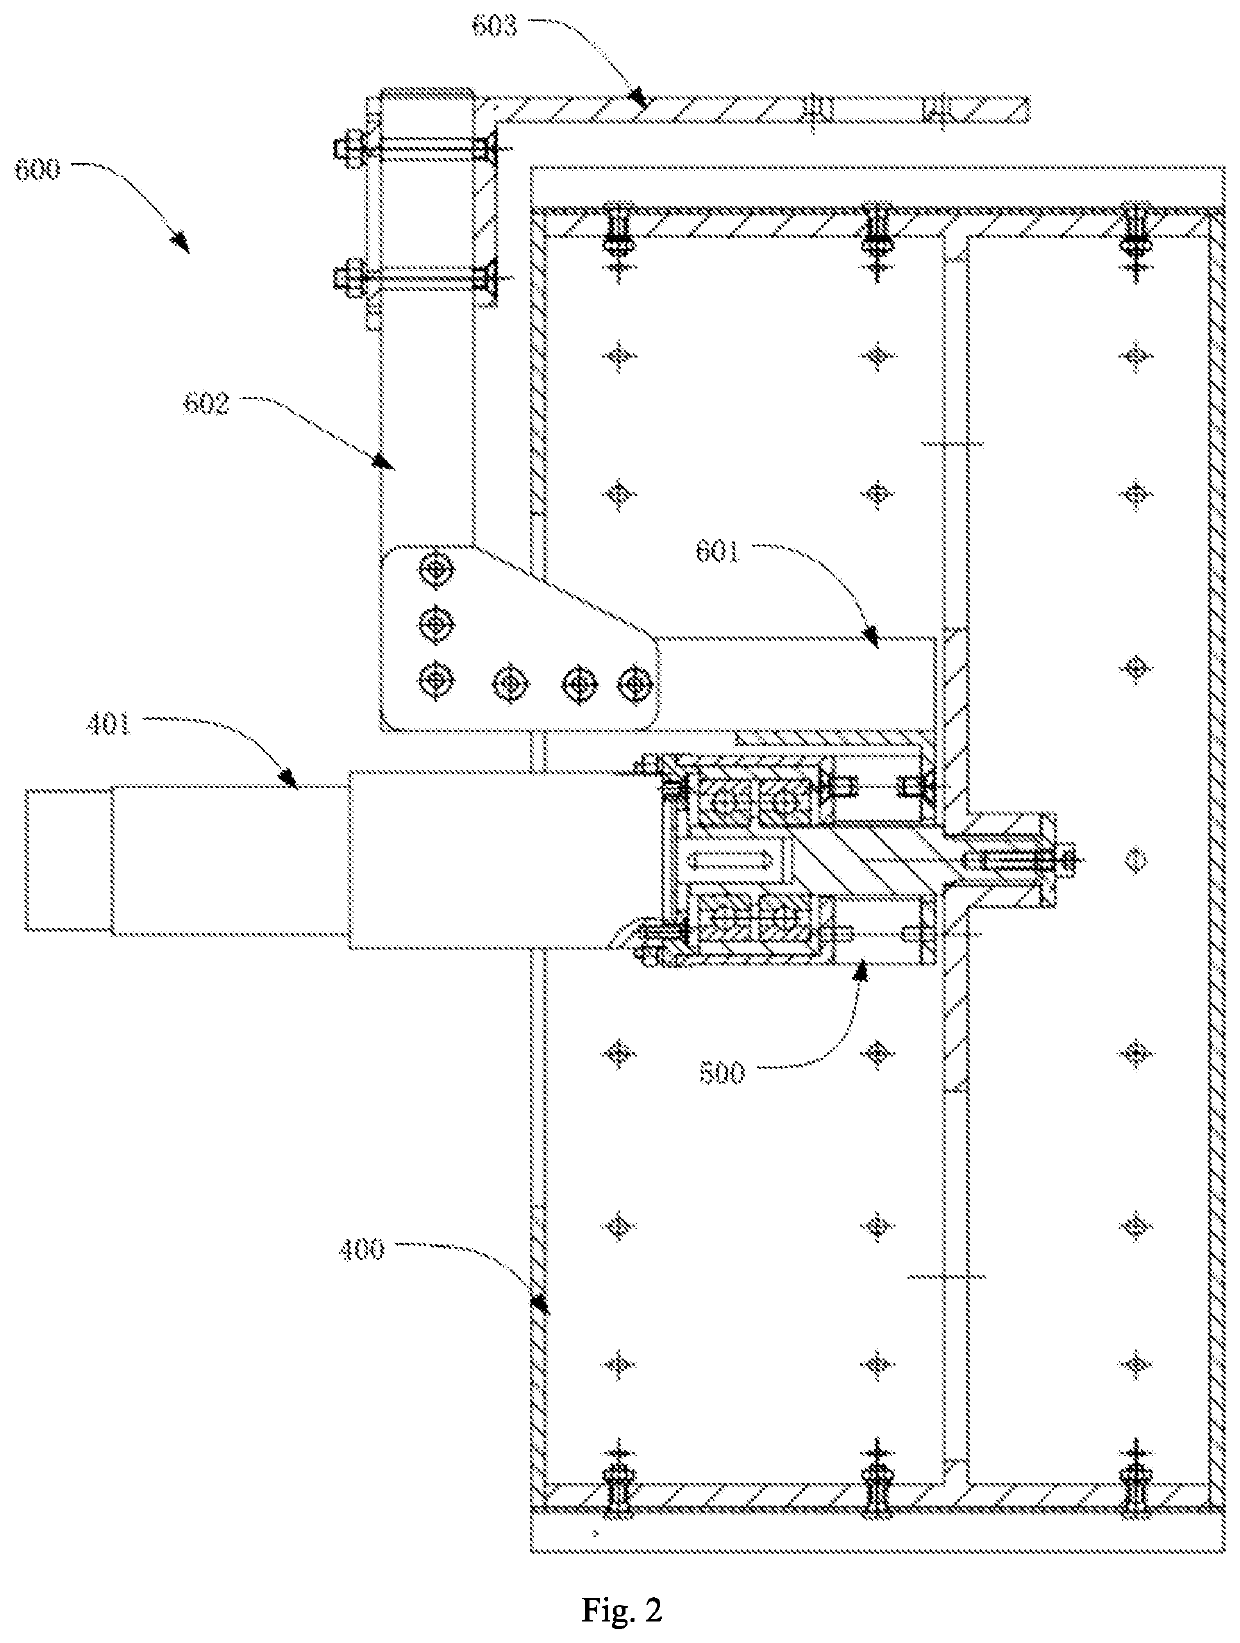
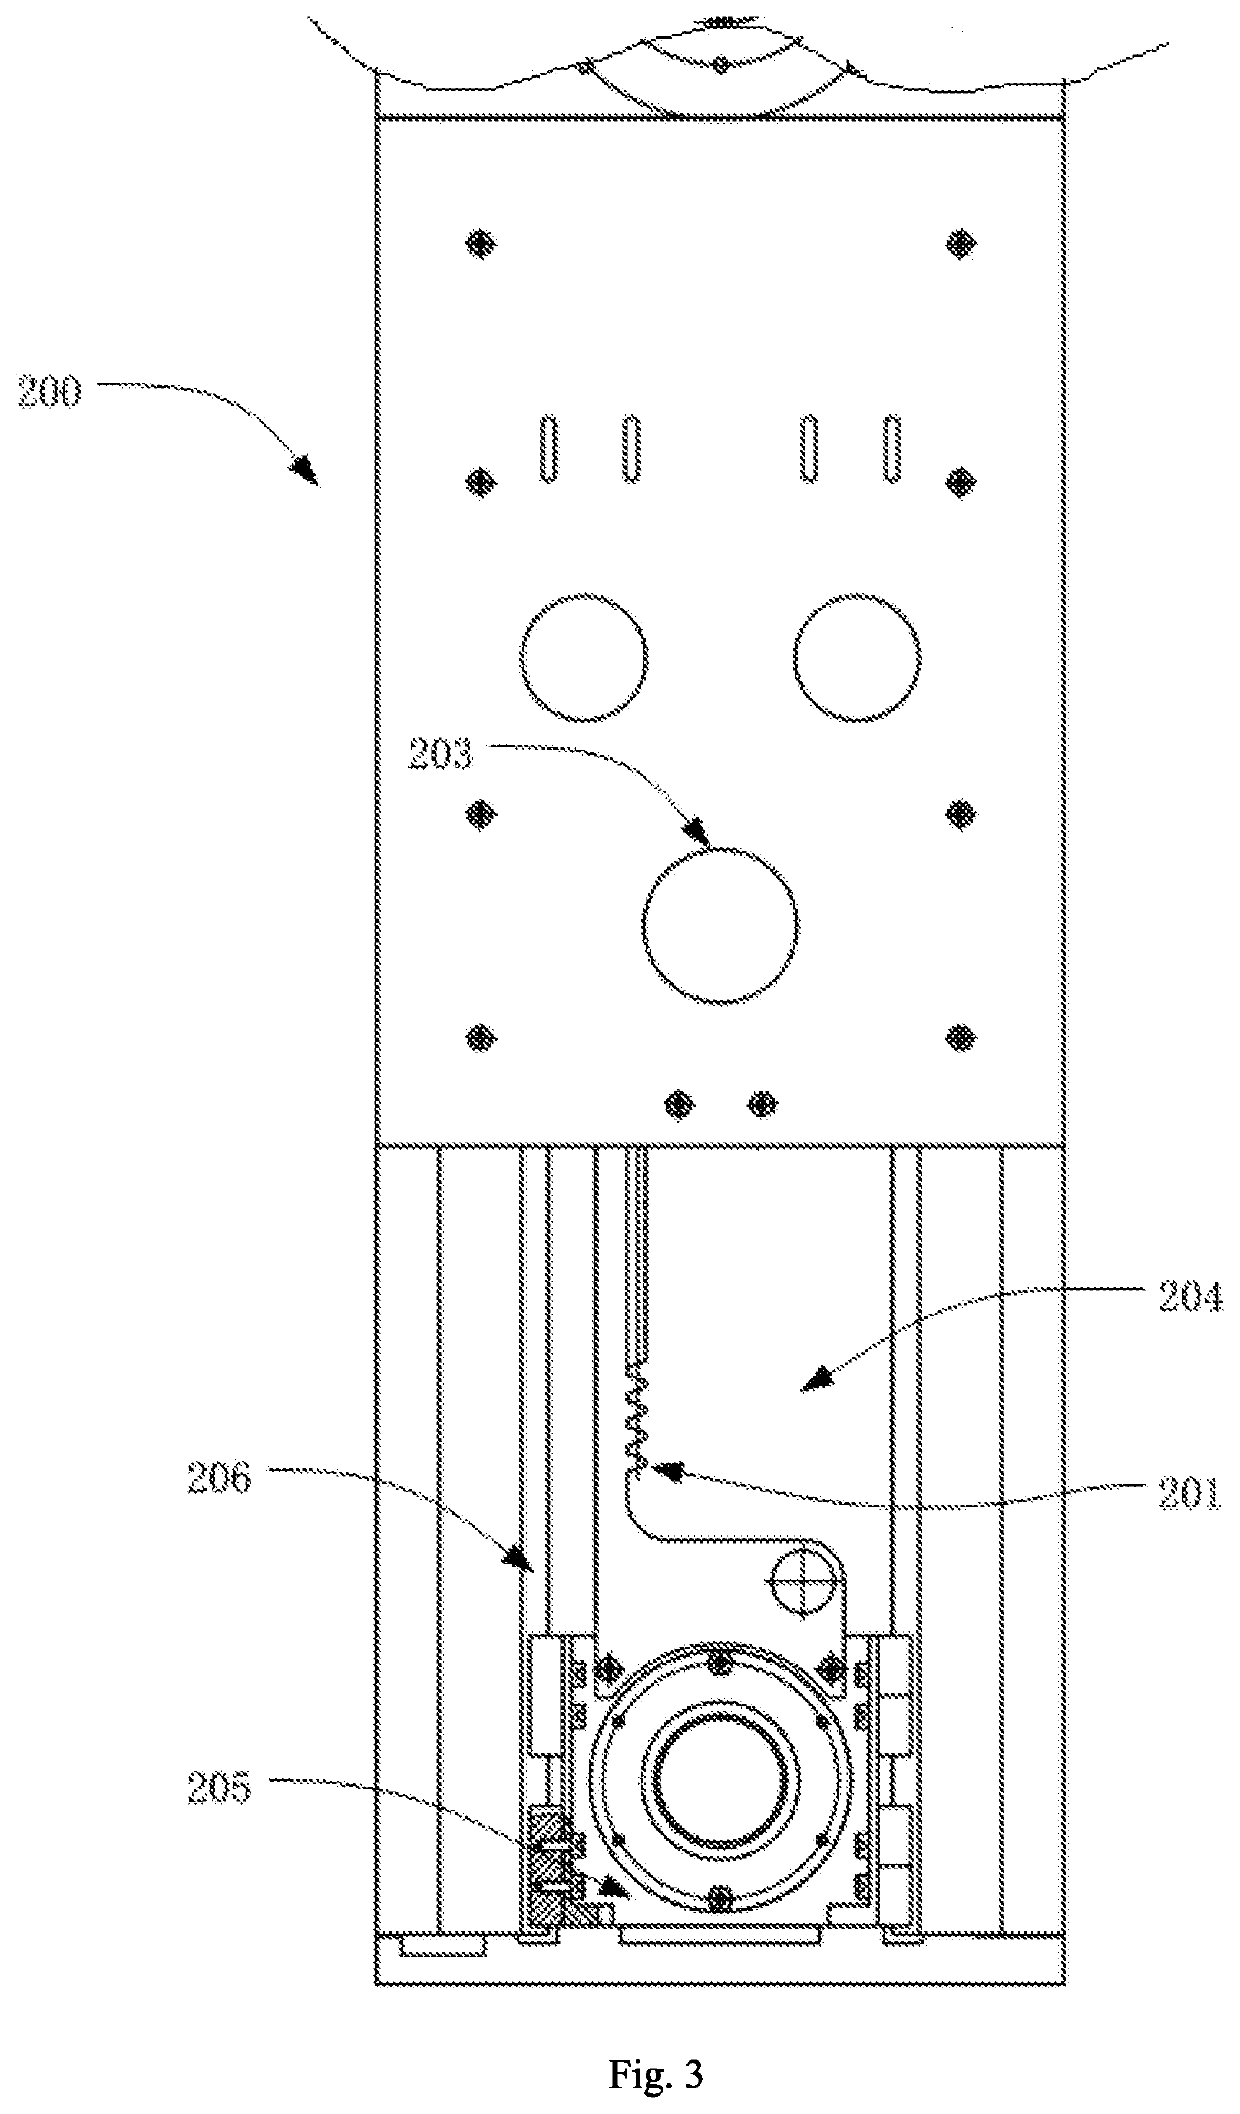
The invention provides a multi-purpose planetary exploration vehicle, and relates to the technical field of planetary exploration. The multi-purpose planetary exploration vehicle includes a box body and a cantilever, first rotating wheels are correspondingly installed on the left side and the right side of the box body, the front end of the cantilever is connected with the box body, second rotating wheels are installed at the rear end of the cantilever, wherein the cantilever can rotate or fix relative to the box body, the second wheels can turn relative to the cantilever, and the first rotating wheels and the second rotating wheels are used for driving the multi-purpose planetary exploration vehicle. Compared with the prior art, the multi-purpose planetary exploration vehicle can effectively explore special geographical locations such as cliffs, craters, meteor craters and lava caves on alien planets.
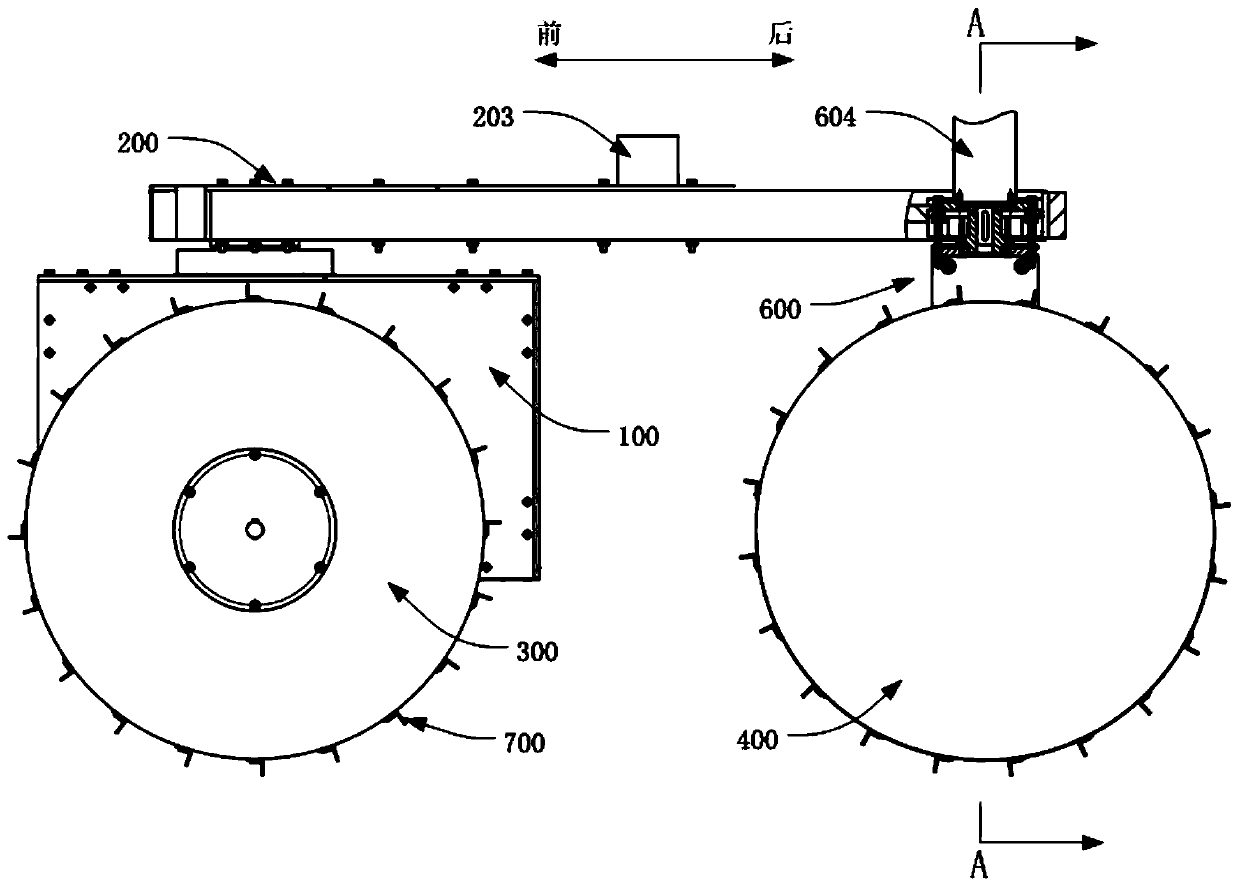
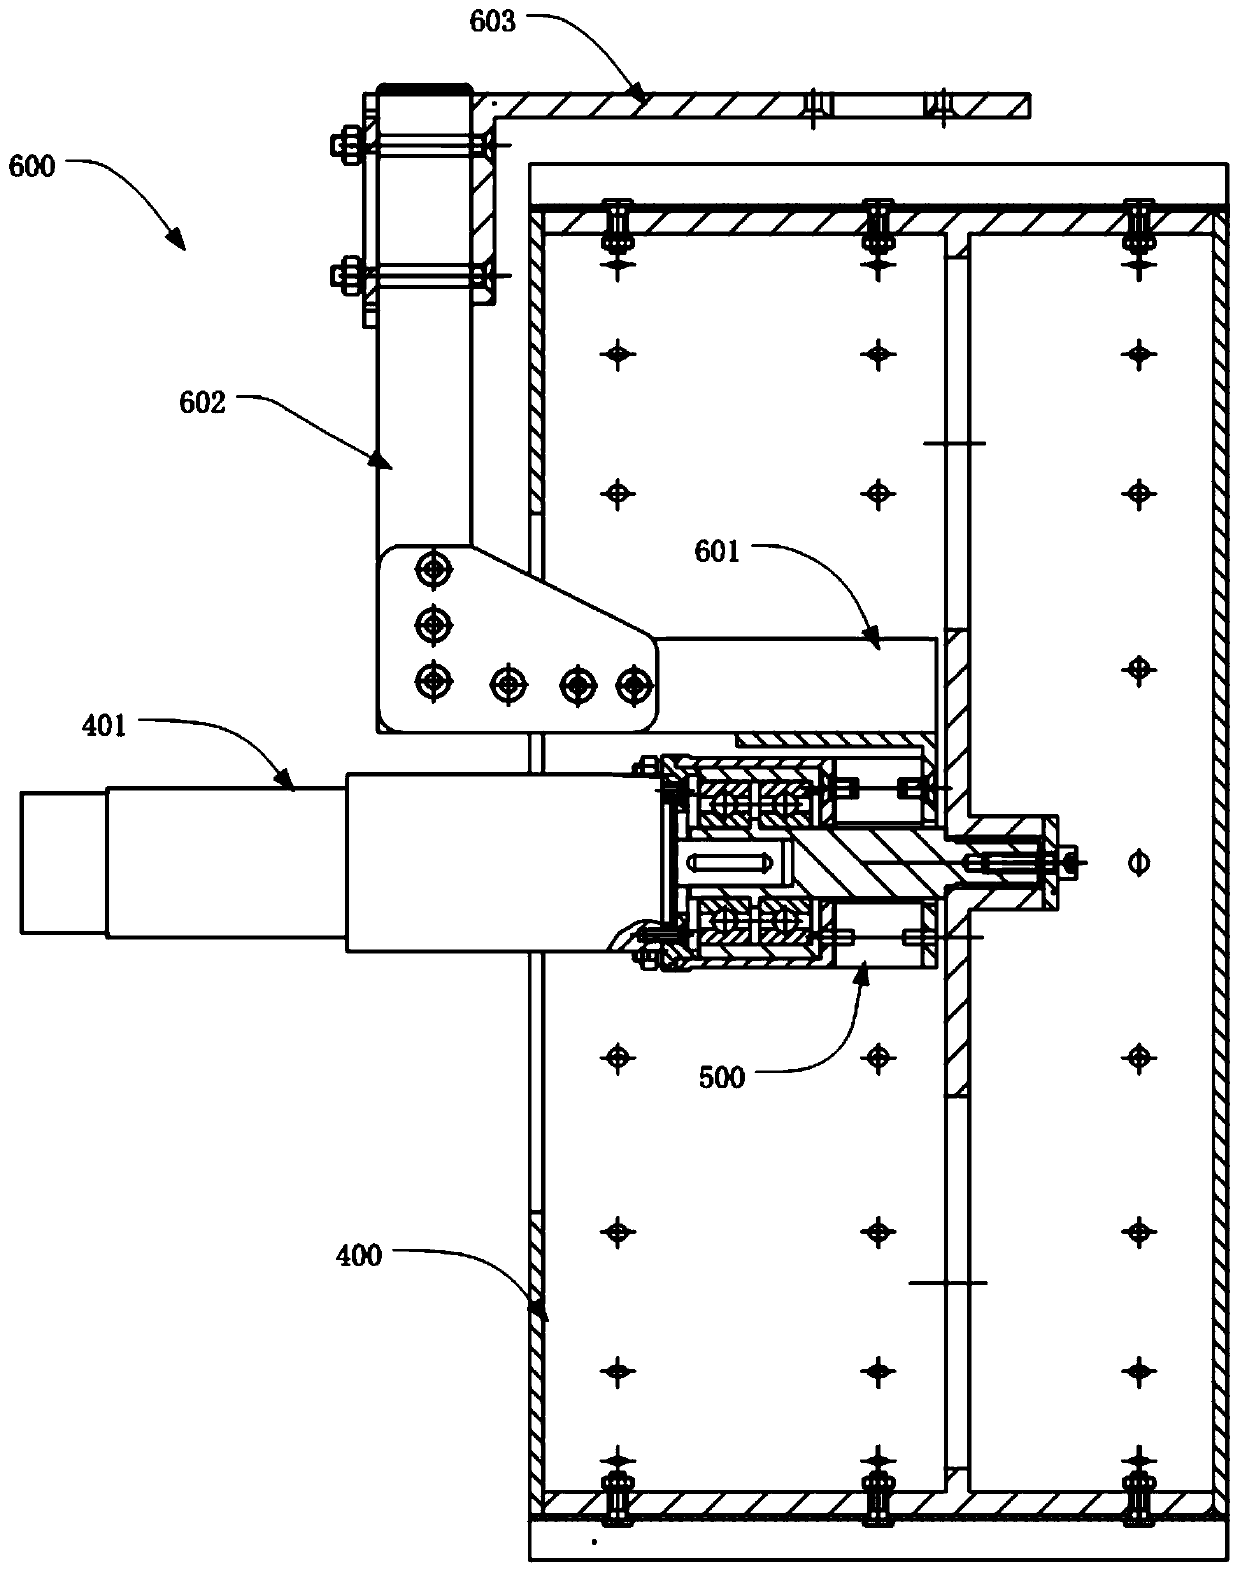
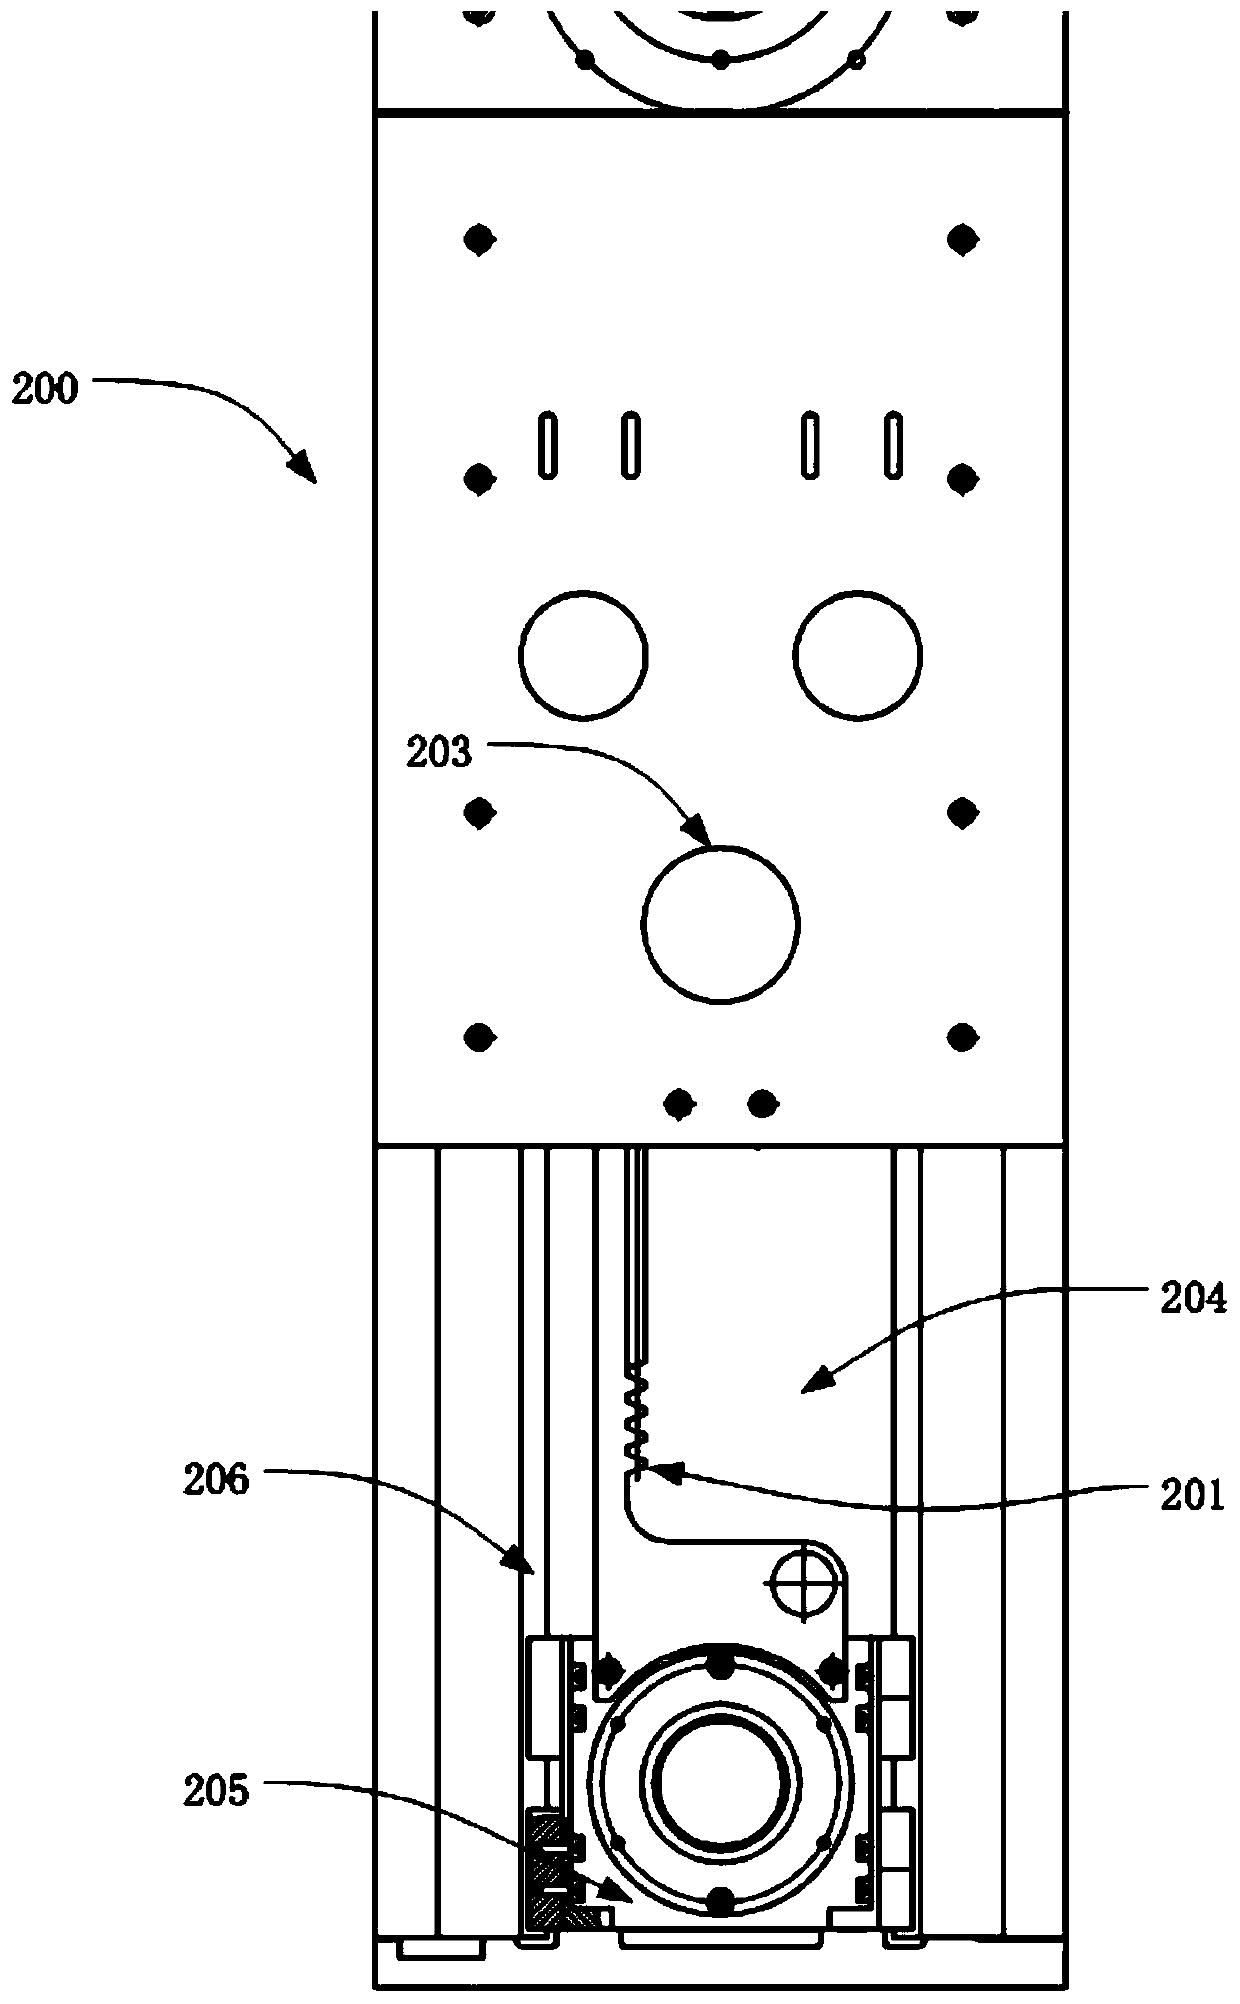
Owner:HARBIN INST OF TECH
Planetary surface navigation landmark matching method based on contour point set
ActiveCN112906573ASimplify complexitySimplify calculation difficultyInstruments for comonautical navigationCharacter and pattern recognitionLandformPlanetary surface
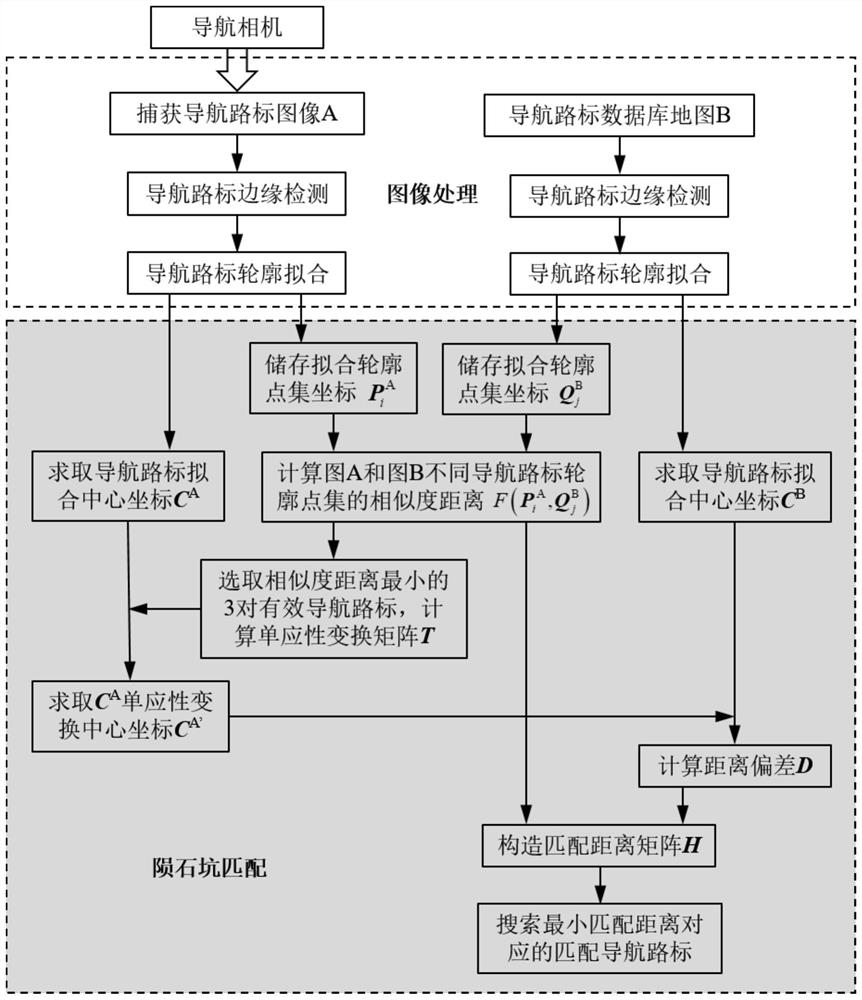
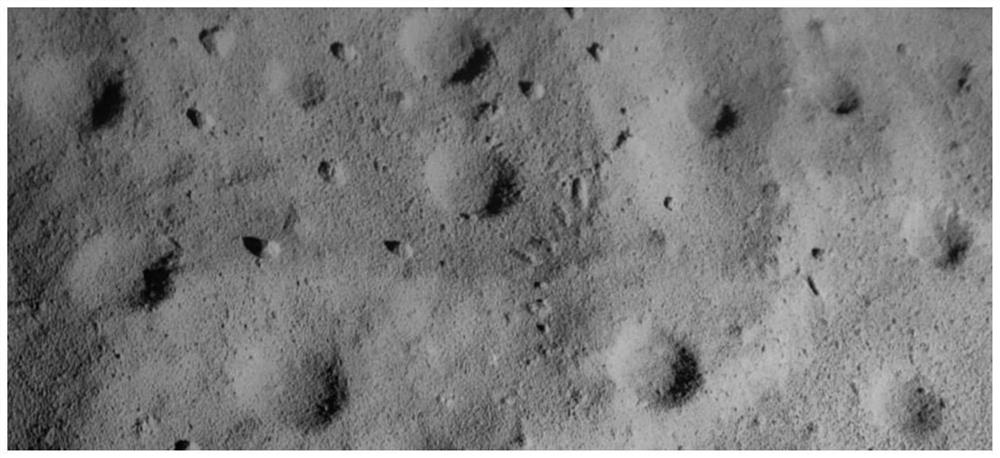
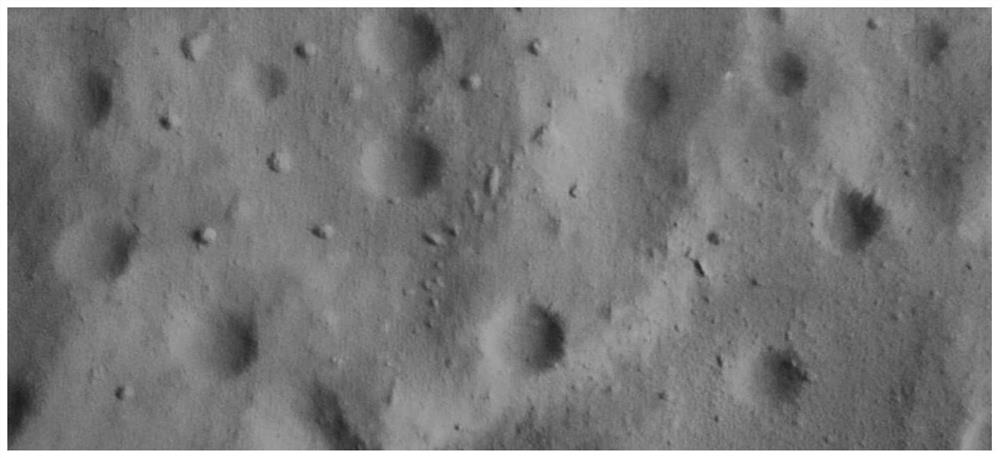
The invention relates to a planetary surface navigation landmark matching method based on a contour point set, and belongs to the field of deep space exploration. According to the invention, the detector carries out navigation landmark edge detection and fitting on a planet surface image A and a database map B, and contour point set coordinates are obtained through navigation landmark fitting contour discretization. The similarity distance of the obtained discrete point set is calculated. Three pairs of navigation road signs with minimum numerical values in the point set similarity matrix are selected as effective matching road signs, and a homography transformation matrix is calculated; and affine transformation coordinates of the center coordinates of the navigation landmarks of the image to be matched is obtained through the homography transformation matrix, distance deviation is calculated by utilizing the center pixel coordinates of the navigation landmarks of the image, a matching distance matrix is constructed, and the navigation landmark with the minimum matching distance is searched as the matching landmark. According to the method, the matching applicable objects are wider, topographies such as meteorite craters, rocks and gullies in optical images can be matched at the same time, and the method is suitable for matching and tracking of sequence images and database maps.
Owner:BEIJING INSTITUTE OF TECHNOLOGYGY
System and method of crater detection and registration using marked point processes, multiple birth and death methods and region-based analysis
ActiveUS10825182B1Maximizing mutual informationImage enhancementImage analysisEarth observationMutual information
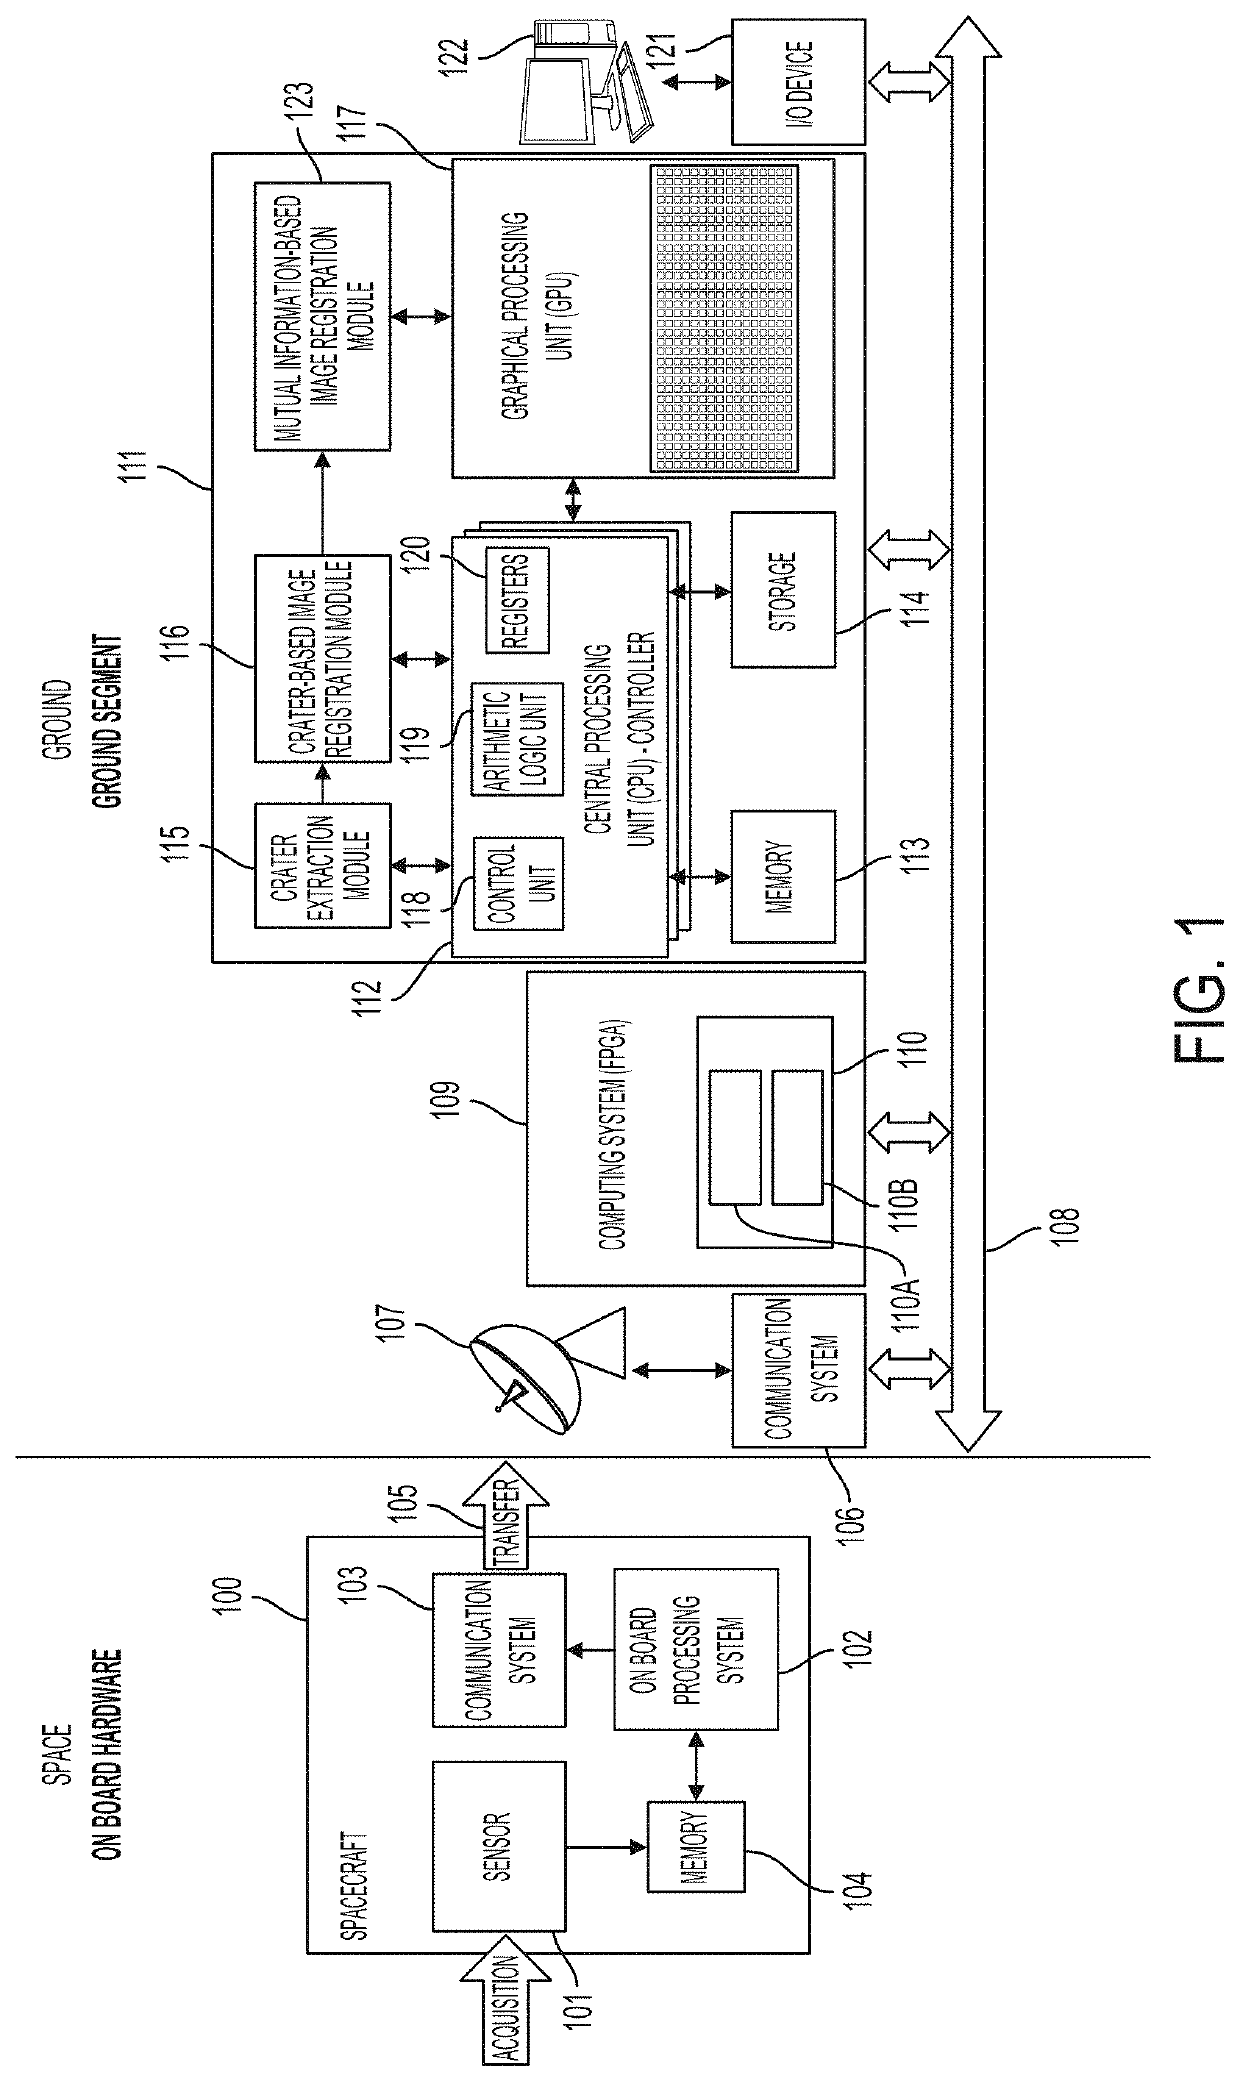
The present invention relates to a novel method and system for crater detection in planetary data based on marked point processes (MPP), effective for various object detection tasks in Earth observation, and for planetary image registration. The resulting spatial features are exploited for registration, together with fitness functions based on the MPP energy, on the mean directed Hausdorff distance, and on the mutual information. Two different methods—one based on birth-death processes and region-of-interest analysis, and the other based on graph cuts and decimated wavelets—are included within the present framework. Experimental results confirmed the effectiveness of the present invention in terms of crater detection performance and sub-pixel registration accuracy.
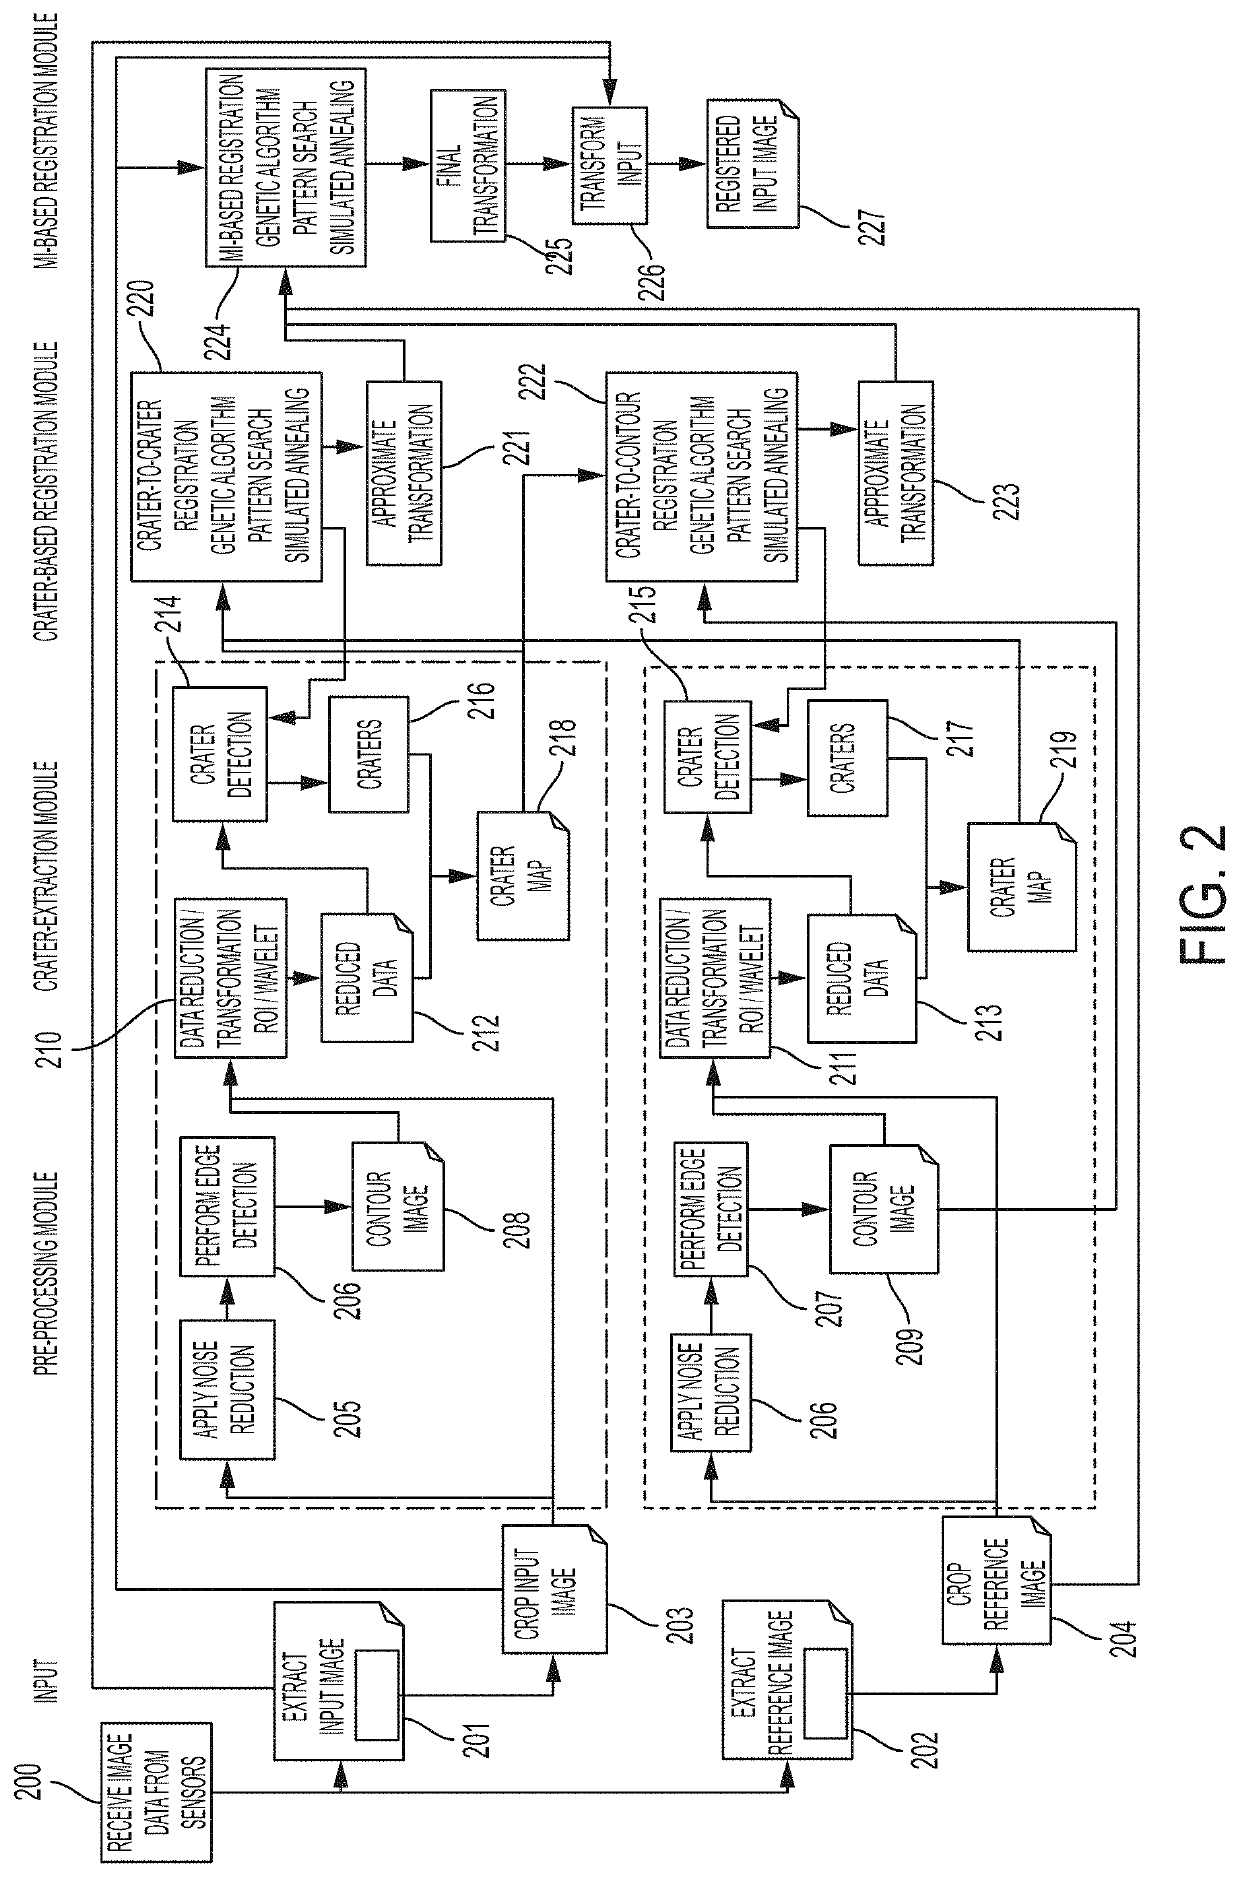
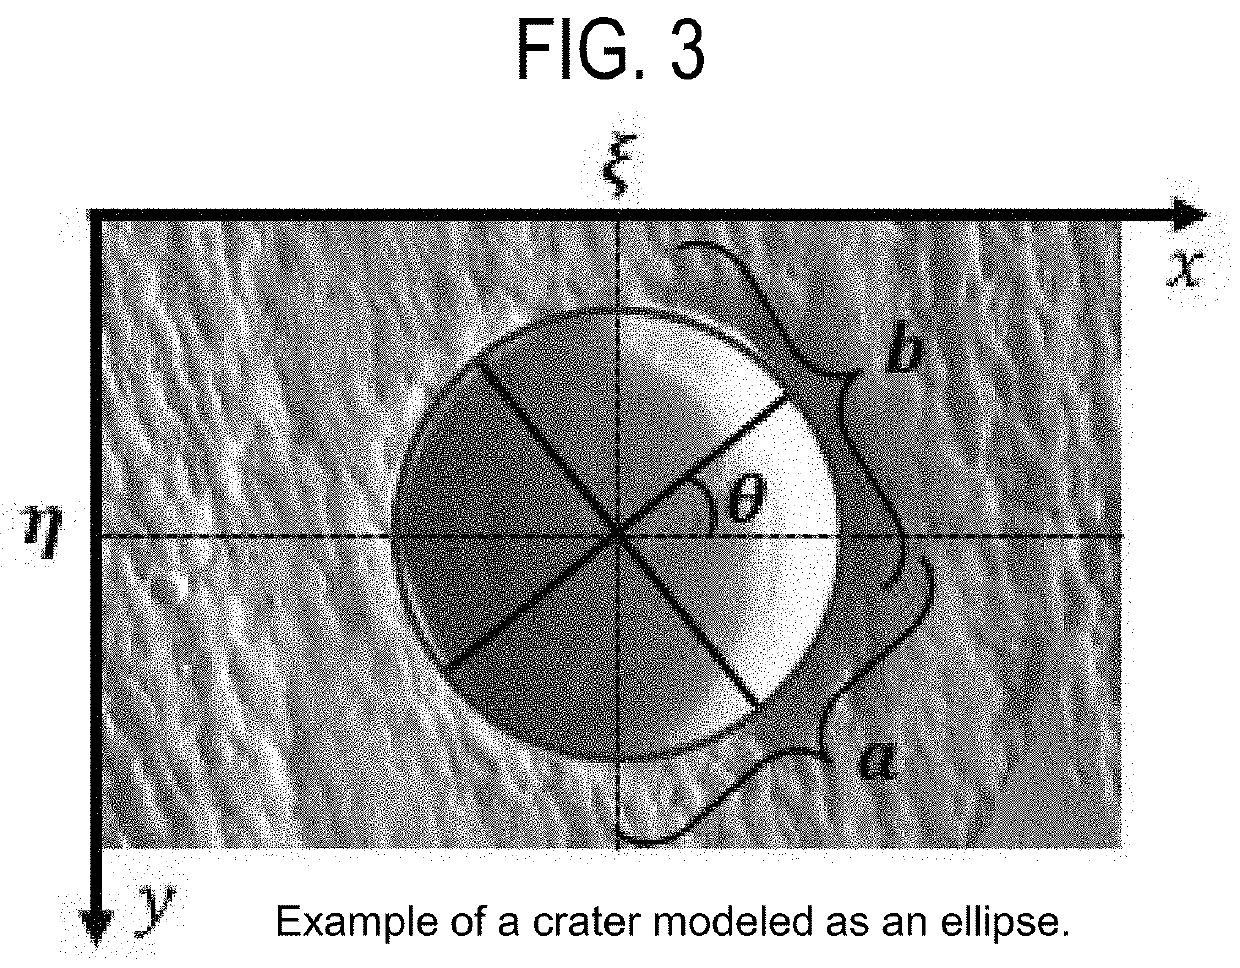
Owner:NASA
Moon water ice detection method based on polarimetric SAR (Synthetic Aperture Radar) multiple parameters
ActiveCN114779173AImprove detection accuracyEliminate distractionsCharacter and pattern recognitionRadio wave reradiation/reflectionMeteorite cratersSynthetic aperture radar
The invention discloses a moon water ice detection method based on polarized SAR (synthetic aperture radar) multiple parameters, which mainly comprises the following steps: selecting abnormal meteorite craters at two poles of the moon as a research area, calculating a circular polarizability ratio (CPR), and selecting an area with the CPR greater than 1; obtaining the power of each scattering component in the research region by using an m-delta decomposition method, and selecting a region in which volume scattering is dominant; calculating a roughness parameter R of the research area, and selecting a relatively flat area based on the parameter; and calculating a backscattering coefficient sigma of the research region, and selecting a region with fewer stones based on the parameter. And judging the area meeting all the conditions as the area where water and ice possibly exist at the same time. According to the method, the polarimetric SAR data of the abnormal meteorite crater is analyzed, the area where water and ice exist is selected based on various parameters, the rough lunar soil surface and interference factors such as sediments and stones are eliminated, and the water and ice detection precision is improved.


Owner:AEROSPACE INFORMATION RES INST CAS
Lunar meteorite crater identification method and device based on depth residual U-Net and storage medium
PendingCN113139592AImprove the effect of identification marksImprove recognition accuracyCharacter and pattern recognitionNeural architecturesLunar meteoriteMeteorite craters
The invention provides a lunar meteorite crater recognition method and device based on a deep residual U-Net and a storage medium, and the method comprises the steps: constructing a U-Net network model based on a residual unit, carrying out the mapping combination of first historical data and second historical data, constructing a training set, inputting the training set into the U-Net network model, carrying out the training, obtaining a first prediction value, screening and de-weighting the first predicted value to obtain a second predicted value, calculating error loss between the second predicted value and the true value of the input data, updating weight parameters of the U-Net network model, and identifying the lunar meteorite crater image by using the trained U-Net network model of which the error loss meets a preset threshold value. Different features of a network model are combined by designing a U-shaped network based on a residual unit, so that the identification effect and accuracy of the lunar meteorite crater are improved.


Owner:CHINA UNIV OF GEOSCIENCES (WUHAN)
A method and system for detecting martian impact craters
The application provides a Mars crater detection method and system, relates to the technical field of planetary remote sensing image processing and target detection, and comprises the following steps: constructing a CAFE-Net network based on a YOLO single-stage detection model, integrating a multi-scale context perception module, a feature enhancement unit and an efficient feature fusion network, training the model after pre-processing MDCD and DACD data sets, and outputting visualized and structured detection results through model inference and non-maximum suppression post-processing, so that the problems of high false detection rate of craters and dome structures and high missing detection rate of small craters in the prior art are effectively solved, the precision and recall rate are improved, the method is suitable for deep space exploration scenes such as Mars probe landing site selection and Mars geological age determination, and can be automatically processed in an end-to-end mode and is convenient to deploy.

Owner:SHANGHAI GESI INFORMATION TECH CO LTD
Deep space lander landing point selection method based on terrain feature quantization
PendingCN120469474AVehicle position/course/altitude controlPosition/direction controlMeteorite cratersSpace probe
The invention discloses a deep space probe landing point selection method based on topographic feature quantification, and the method comprises the steps: constructing a multi-target topographic feature optimization model through analyzing the parameters of a landing region, such as the topographic slope, the surface roughness, the obstacle distribution and the regional area, and achieving the automatic selection of a safe landing point. The method comprises the following specific steps: firstly, detecting spatial distribution of potential obstacles such as rocks and meteorite craters, and secondly, quantitatively analyzing topographic feature parameters such as topographic roughness, gradient change rate and topographic relief; and finally, an optimal landing position is determined under multiple terrain constraint conditions by using an optimization search algorithm, so that the landing safety and task success rate of the detector are effectively improved. According to the method, the safe landing point of the detector is accurately obtained by innovatively applying terrain feature quantification and a search algorithm, so that effective detection of a safe position in a landing area is efficiently realized, and safe landing of the detector is practically guaranteed.

Owner:JINLING INST OF TECH
Lunar surface operation multi-robot collaborative knitting and material adding system and knitting method
The invention discloses a lunar surface operation multi-robot collaborative weaving material adding system and a weaving method. The multi-robot collaborative weaving material adding system is composed of a communication base station, an energy base station, a supporting rod and a plurality of weaving robots. The knitting robot is composed of moving wheels, a moving chassis, a wire feeding mechanism, a knotting device, a power battery, a battery cover, a control box and a sensing system. The weaving method comprises the steps that S1, the weaving robot deploys the supporting rod at the edge of a lunar surface meteorite crater; s2, the weaving robot fixes the tail end of a carbon fiber yarn in a yarn feeding mechanism to a supporting rod; s3, a plurality of weaving robots move in the meteorite crater, and the wire feeding speed is controlled to be consistent with the moving speed; and S4, the multiple weaving robots move according to the planned path, and net-shaped protection structure weaving is completed in a mutual knotting and supporting rod winding mode. By deploying the weaving robot formation on the lunar surface, the purpose of unmanned construction of the protective net on the lunar surface can be achieved.

Owner:SOUTHEAST UNIV
Lighter (Meteor Crater 15043)

Owner:王军伟
A Lander Visual Navigation Method Based on Multi-source Features
ActiveCN107144278BImprove stabilityAvoid problems that cannot be used for absolute position estimationNavigational calculation instrumentsMeteorite cratersDeep space exploration
The invention relates to a multi-source feature based visual navigation method of a lander, belongs to the technical field of deep space exploration, and aims at solving the problem of estimating the absolute horizontal position of the lander in descending and landing. The method is characterized in that the advantages that meteor crater feature absolute location information is known and landing end corner feature information is rich are utilized, the problems that the quantity of the landing end meteor crater features cannot meet the navigation and positioning condition and the corner feature cannot be applied to the absolute location estimation, can be avoided, and as a result, the stability of navigation algorithm is improved; and the lander can accurately land.
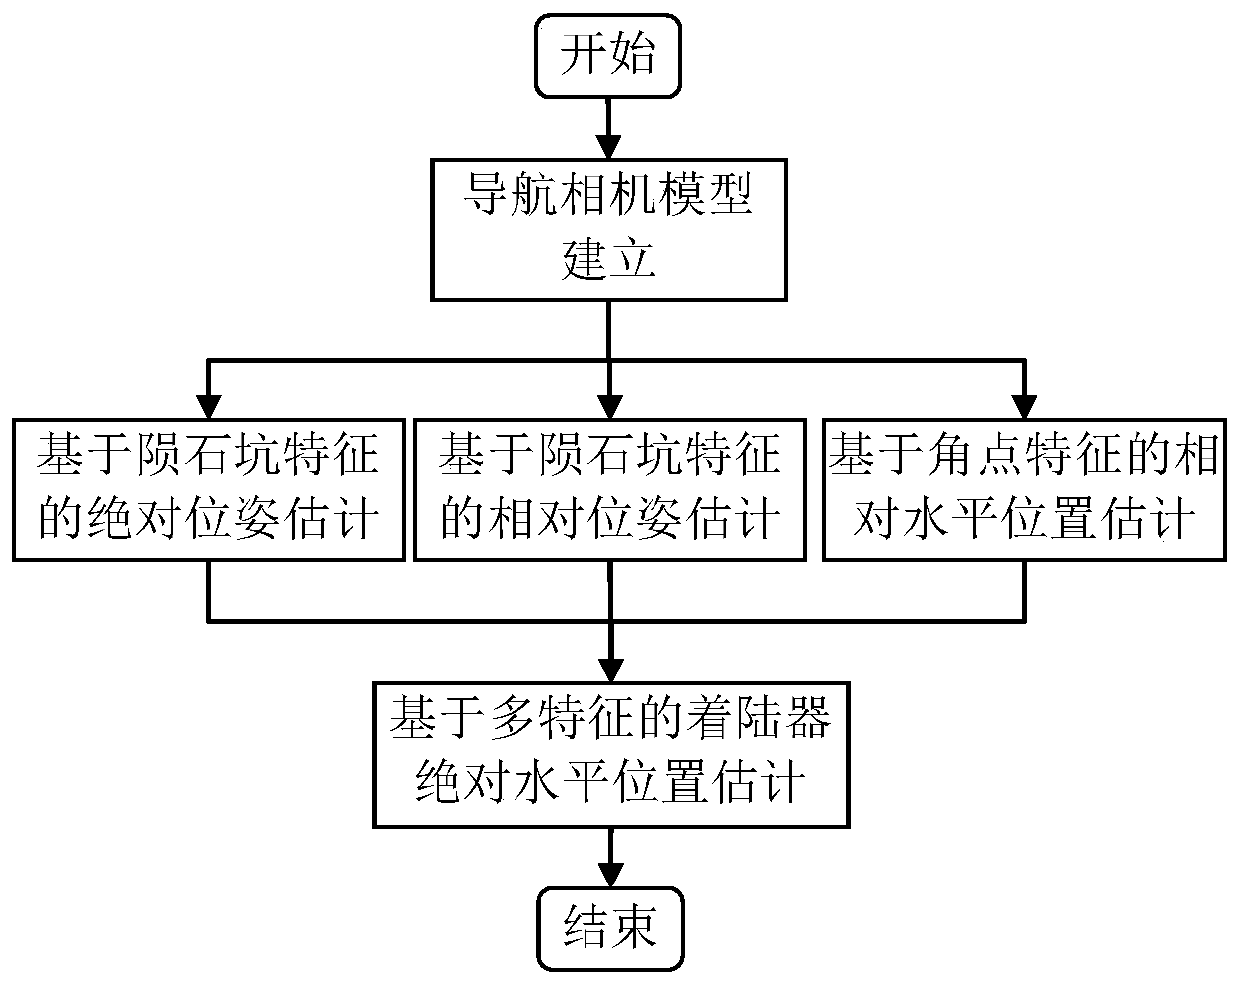
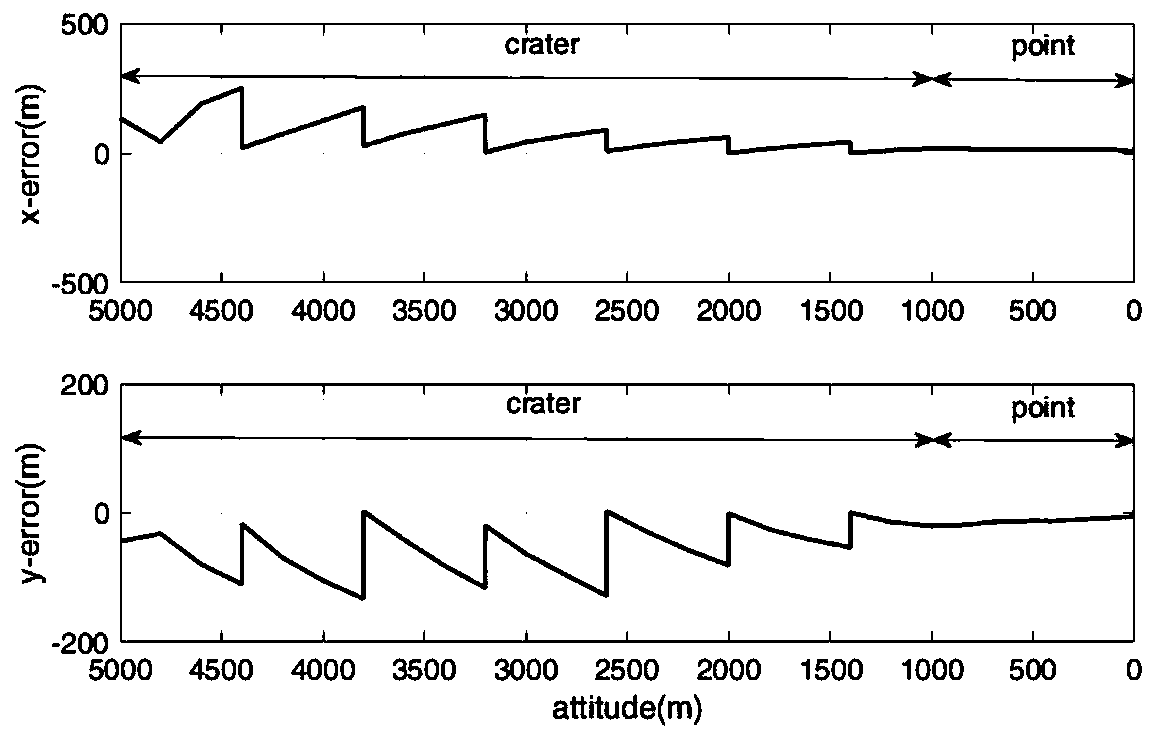
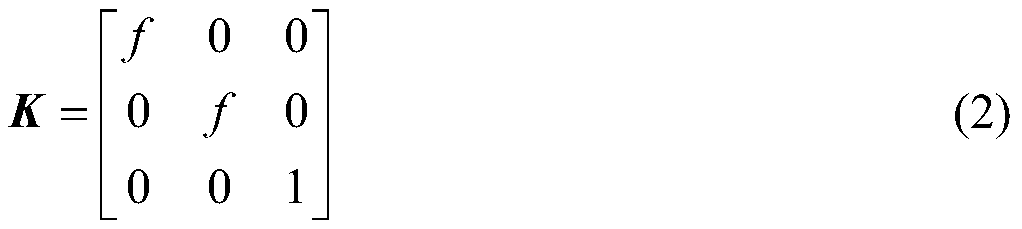
Owner:BEIJING INSTITUTE OF TECHNOLOGYGY
Lamination cylinder
A lamination cylinder includes a surface structure, on which a plurality of craters is defined having a different geometry and a random distribution. Some of the craters are partially superimposed with respect to each other.


Owner:TENOVA
Gravity energy storage system suitable for meteorite crater environment
PendingCN121689577AElectrical storage systemSingle network parallel feeding arrangementsDC - Direct currentMeteorite craters
A gravity energy storage system suitable for a meteorite crater environment comprises a gravity energy storage device, a motor drive / power generation device and an energy conversion and power supply device. The motor driving / generating device comprises a permanent magnet synchronous motor and a direct current motor; the energy conversion and power supply device comprises a first bidirectional power converter, a second bidirectional power converter and a boost converter, the second bidirectional power converter is electrically connected with the photovoltaic array through the boost converter and electrically connected with a power grid through the first bidirectional power converter, and the direct current motor is electrically connected with the photovoltaic array through the boost converter. And the first bidirectional power converter is electrically connected with a power grid. The natural elevation difference of the meteorite crater is utilized, rocks around and inside the meteorite crater serve as gravity energy storage loads, and storage and release of gravitational potential energy are achieved through lifting and lowering of a mine car or a cable car along a transportation channel. According to the system, a photovoltaic array and a power grid are used as dual-power input, and bidirectional conversion and grid-connected output of energy are realized through switching between a driving mode and a power generation mode by a bidirectional power converter and a motor, so that the dependence of a gravity energy storage system on an artificial structure and an external weight is reduced, and the adaptability of the system to a complex terrain environment is improved.

Owner:SHANGHAI JIAOTONG UNIV
An Observability Detection Method for Crater Feature Mis-Matching
ActiveCN107703522BGuaranteed stabilityImprove real-time performanceScene recognitionSatellite radio beaconingMeteorite cratersCelestial body


Owner:BEIJING INSTITUTE OF TECHNOLOGYGY
Lunar meteorite crater detection method based on SA-BRU-Net
PendingCN121074625ACharacter and pattern recognitionBiological modelsComputational scienceMeteorite craters
The invention discloses a moon meteorite crater detection method based on SA-BRU-Net. The processing method comprises the following steps: cutting and preprocessing a DEM image; performing projection conversion to manufacture a meteorite crater data label; the SA-BRU-Net model is trained; testing and storing the model; the SA-BRU-Net model outputs a meteorite crater edge segmentation result; extracting the position size of the meteorite crater; repeatedly removing the meteorite craters; and evaluating the model. According to the method, lunar remote sensing image data is utilized, a bottleneck residual error is adopted to replace a traditional effective residual error based on a U-Net model, and a space attention mechanism is introduced. The improvement not only reduces network parameters, but also improves the identification precision of the lunar meteorite crater.


Owner:HOHAI UNIV
A method and device for generating crater terrain based on Wally noise
A method and device for generating crater terrain based on Wally noise, the method comprising the steps of: generating grid points according to a fixed step; randomly moving the grid points, and the moving distance is less than half of the fixed step; One-half of the distance between the grid point and the nearest grid point is used as the radius of a random circle with each grid point as the center of the circle, and a random circle is generated; based on the preset coordinate position and the preset height ratio value, Calculate the height value of the preset coordinate position; generate the crater terrain according to the height value of the preset coordinate position and a random circle. The crater terrain generation method and device based on Wally noise of the present invention outputs a height value corresponding to the sampling point based on the input coordinate value of a sampling point, so that craters can be randomly generated in the terrain scene, and then used to simulate The effect of craters or volcanic craters.
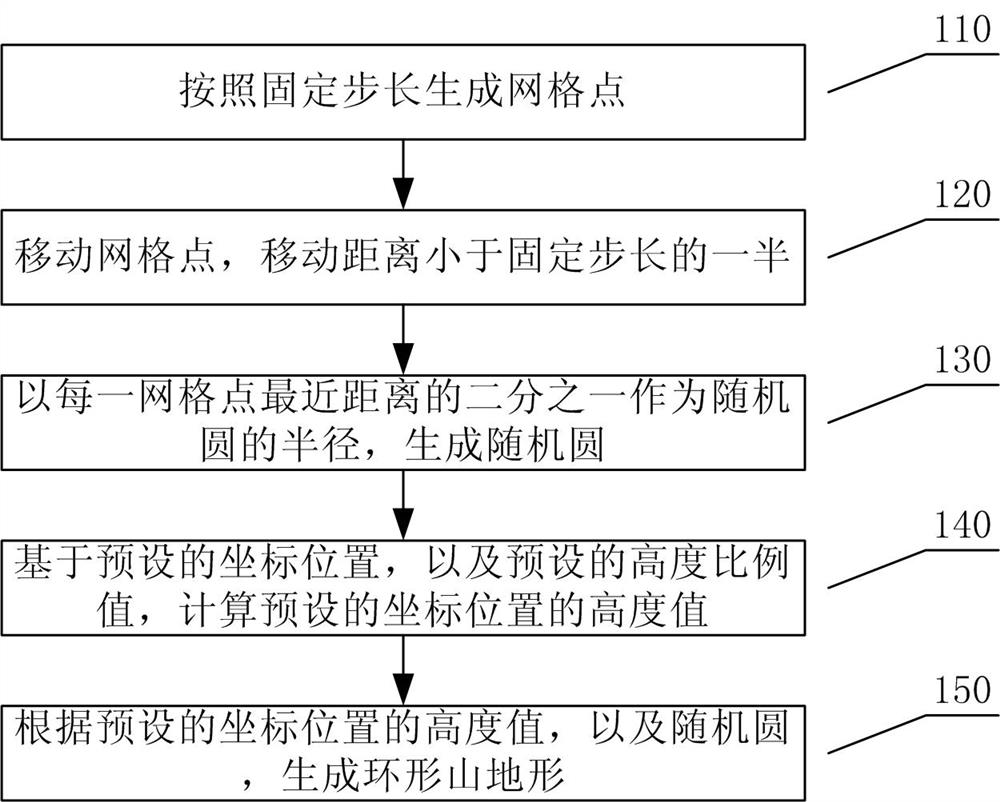
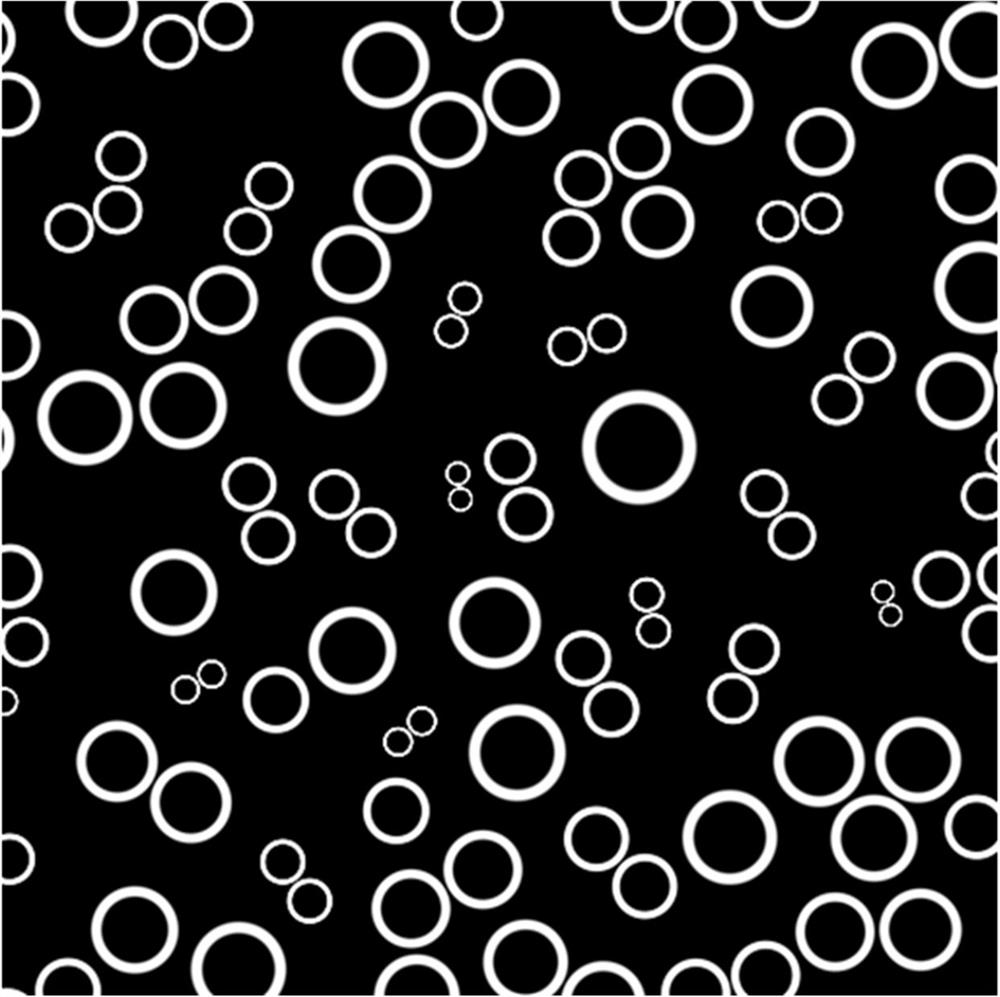
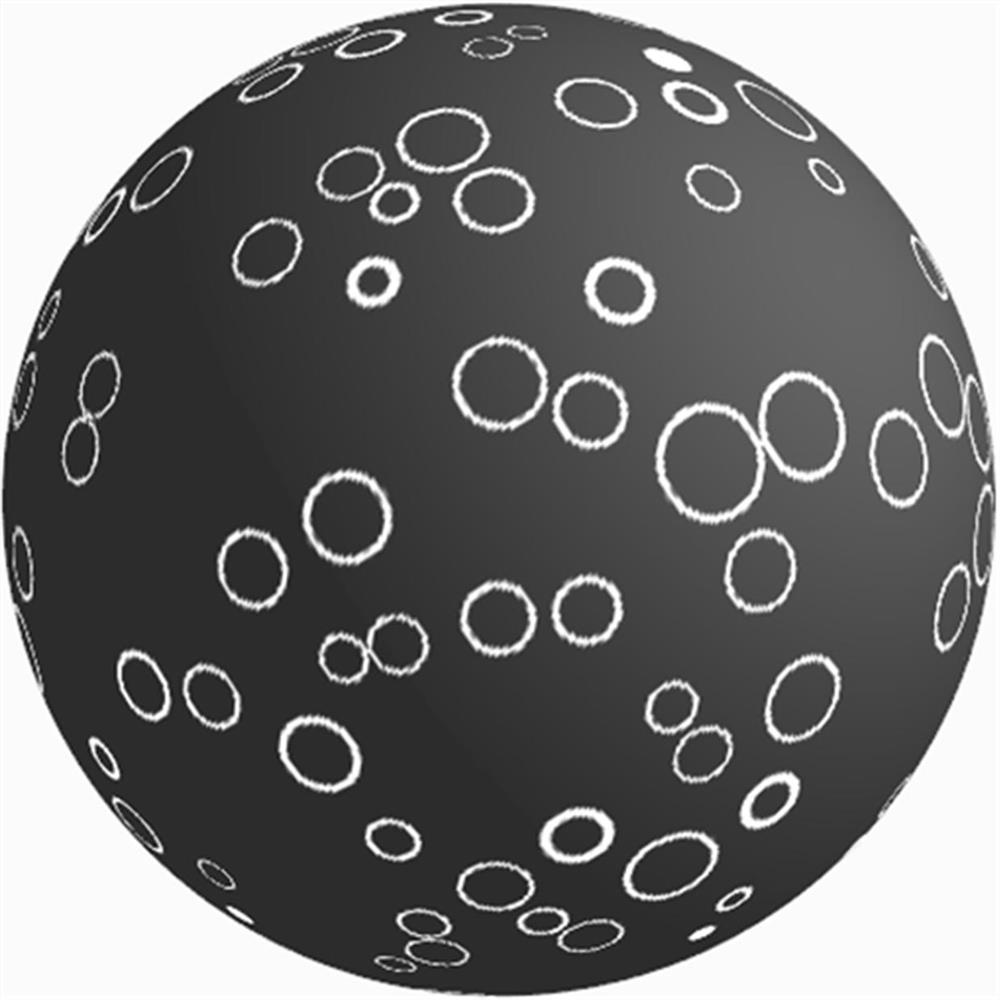
Owner:SNAIL GAMES
Optimal method for evaluating observational information of landmarks on the surface of irregular small celestial bodies
ActiveCN110095123BHigh precisionImprove navigation accuracyNavigational calculation instrumentsInstruments for comonautical navigationCamera imageImaging processing
The invention, which belongs to the autonomous navigation, discloses a road sign observation information evaluation optimization method of a small irregular celestial body surface. The method comprises: on the basis of an image processing algorithm, detecting and extracting meteorite crater observation information of a small celestial body surface in a navigation camera image; carrying out ellipsefitting and meteorite crater center positioning on the detected and extracted meteorite crater and calculating an error uncertainty matrix R of the meteorite crater based on uncertainty propagation characteristics; according to a pixel coordinate and an image line coordinate of a navigation road sign observed in the navigation image, constructing an observation matrix H; and constructing an evaluation index function based on the R and H and selecting an optimal navigation road sign preferably with consideration of the observation error and position formation distribution of the navigation road sign, According to the selected optimal meteorite crater navigation road sign, a position attitude of a deep space detector is determined, so that the navigation accuracy of the position attitude ofthe deep space detector is improved.


Owner:BEIJING INSTITUTE OF TECHNOLOGYGY
A system for geographically context-related crater detection
ActiveDE202025107756U1Instruments for comonautical navigationCharacter and pattern recognitionTerrainData pack
A system for geographically context-related crater detection, consisting of: a camera configured to capture raw images of the descent route; one or more integrated sensors configured to provide terrain context data, including altimeter, inertial measurement, or geological mapping information; a context-based super-resolution module (CISR) configured to produce a super-resolution image based on terrain context data; a crater detection network configured to detect one or more craters from the high-resolution image; a graph-based relational matching module configured to match the detected craters with a pre-calculated crater database; and an adaptive state estimation module configured to generate a spacecraft state output based on the matched crater pattern
Owner:PAUL ADITRI HOOGHLY +3
Meteorite crater matching method based on area ratio


Owner:HARBIN INST OF TECH
Multi-purpose planet rover
PendingUS20220289405A1Simple body structureReduce overall weight and volumeCosmonautic power supply systemsSteering linkagesMeteorite cratersEngineering
A multi-purpose planet planetary exploration rover is provided in this invention, which relates to the field of planet exploration. The multi-purpose planetary exploration rover includes a case body, mounted with a first wheel at left and right sides respectively; and a cantilever, having a front end connected to the case body, a rear end of the cantilever being mounted with a second wheel; wherein the cantilever is rotated or fixed relative to the case body, the second wheel is steered relative to the cantilever, and the first wheel and the second wheel are used to drive the multi-purpose planetary exploration rover. Compared with the prior art, the multi-purpose planetary exploration rover of this invention can effectively explore special geographic locations such as cliffs, volcanic craters, craters and lava caves on alien planets.
Owner:HARBIN INST OF TECH
Lunar surface landing slope distance measurement mathematical simulation method based on fine simulation terrain
ActiveCN111553049ARealistic terrain simulation effectMath simulation speed is not affectedDesign optimisation/simulationSpecial data processing applicationsTerrainMeteorite craters
The invention relates to a lunar surface landing slope distance measurement mathematical simulation method based on a fine simulation terrain, which comprises the following steps: (1) randomly generating a fine simulation terrain near a landing point by using matlab and superposing the fine simulation terrain on a real terrain to form a simulation terrain, and storing the simulation terrain according to a pre-defined grid; (2) calculating the elevation of the footprints of the ranging beams in the grids by adopting a triangular segmentation and linear interpolation method; and (3) correcting the slope distance by using the elevation at the footprint of the ranging beam. The method for randomly generating the fine simulation terrain near the landing point by utilizing matlab provided by theinvention can be used for simulating the diversity of meteorite crater distribution. According to the lunar landing slope distance measurement mathematical simulation method based on fine terrain simulation, the elevation of any point in the grid calculated through the triangular segmentation and linear interpolation method is closer to the real situation, and terrain jump is avoided, and the slope distance is corrected through the elevation of the footprints of the ranging beams, and the simulation precision of the slope distance is improved.


Owner:BEIJING INST OF CONTROL ENG
A celestial body crater image instance segmentation method and system based on a text prompt
The application discloses a celestial body meteor crater image instance segmentation method and system based on a text prompt, relates to the technical field of image segmentation, and comprises the following steps: first, receiving a celestial body meteor crater image, using a SAM large model to perform image segmentation on the celestial body meteor crater image to obtain an image segmentation mask; filtering and screening the image segmentation mask, filtering out non-circular and non-elliptical image segmentation masks to obtain a filtered image segmentation mask; receiving a text prompt, using an image-text pre-training model to perform feature extraction on the filtered image segmentation mask and the text prompt to obtain M text feature vectors and image feature vectors, performing similarity calculation on the M text feature vectors and image feature vectors to obtain M similarity scores, selecting a text feature vector with the largest similarity score with the image feature vector as a classification result, and realizing instance segmentation on the celestial body meteor crater image.

Owner:DEEP SPACE EXPLORATION LABORATORY

A crater composite feature matching method
The present invention discloses a crater composite feature matching method, which relates to the field of image feature matching. The method comprises: first, extracting the crater center point set based on the crater identification result, using the Delaunay algorithm to obtain the crater triangle set, using the triangle and the crater corresponding to its vertex as the feature primitive, and constructing the crater geometric configuration feature network; secondly, using the geometric information of the feature primitive, constructing a shape descriptor that integrates the crater radius constraint; then, selecting the inscribed circle of the triangle as the support area within the feature primitive, and constructing a regional descriptor with scale, rotation and illumination invariance; then, performing weighted fusion on the shape descriptor and the regional descriptor to generate a composite feature descriptor; finally, using the nearest neighbor algorithm to match the generated feature descriptor. The present invention introduces geometric information constraints and regional gradient feature descriptions into the image feature matching method, maintains the matching accuracy when the image undergoes scale, rotation and illumination transformations, and can complete the task of accurately matching small celestial body crater images.

Owner:QINGDAO UNIV OF SCI & TECH
Evaluation and Selection Method of Optical Navigation Landmarks on Asteroid Surface
ActiveCN109708643BHigh precisionImprove navigation accuracyNavigational calculation instrumentsInstruments for comonautical navigationCamera imageImaging processing
The invention discloses an asteroid surface optical navigation road sign evaluation selection method, is especially suitable for a navigation system which uses meteor craters as road signs to autonomously determine the position and the attitude of a deep space detector and belongs to the field of autonomous navigation. The method is characterized in that the image processing algorithm is utilizedin navigation camera images to detect and extract the asteroid surface meteor crater information; elliptic fitting and meteor crater center positioning are performed on the detected meteor crater information; a fitted elliptic equation is utilized, according to the uncertainty propagation characteristics, an error covariance matrix R of the meteor crater is obtained, and error elliptic long and short half axes a and b describing the uncertainty of crater errors are obtained as indexes for evaluating the observation quality of the meteor crater. The accurate and feasible positioning road sign autonomous selection method is provided for the deep space detector, the best navigation road signs are selected, so accuracy of navigation road sign selection of the deep space detector is improved, and thereby navigation accuracy of the position and the attitude of the deep space detector is improved.


Owner:BEIJING INSTITUTE OF TECHNOLOGYGY