
Patents
Literature
1237results about "Work measurement" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Motor instantaneous torque measuring method and system based on high-bandwidth sensor
The invention relates to the technical field of motor detection, and discloses a motor instantaneous torque measurement method and system based on a high-bandwidth sensor, and the method comprises the steps: synchronously collecting a torque signal and a multi-source interference variable through the high-bandwidth sensor, and forming an original torque sequence after time synchronization superposition; extracting disturbance frequency characteristics through multi-scale wavelet transform and spectral analysis; a pre-trained adaptive filter model is utilized to generate a filter coefficient matched with the working condition, and primary filtering is completed; residual fluctuation is suppressed in combination with Kalman state estimation, and an optimized torque estimation value is obtained; parameter self-adaptive compensation is realized through online calibration weight updating, and a stable torque measurement sequence is output; load abrupt change pre-judgment and threshold value dynamic updating are achieved based on time-frequency correlation analysis, and finally rapid measurement convergence after working condition abrupt change is ensured through a closed-loop reset mechanism. According to the method, the problem of low instantaneous torque measurement precision in the prior art can be solved.

Owner:LANZHOU ELECTRIC CORP
Automatic torsion testing machine
InactiveCN103217240AImprove work efficiencyReduce operator fatigueWork measurementTorque measurementIndustrial engineering
The invention discloses an automatic torsion testing machine. The automatic torsion testing machine comprises a first table support, a second table support, a third table support, a fourth table support and stand bars, wherein the framework of the whole torsion testing machine is formed by the first table support, the second table support, the third table support and the fourth table support, the stand bars are installed on the bottom corners of the framework, a working table is arranged above the third table support and the fourth table support, a second part detecting sensor is installed above the third table support and on the working table, and a first part detecting sensor is installed above the fourth table support and on the working table. The automatic torsion testing machine has the advantages that working efficiency is improved, labor intensity of workers is relieved, and the integral advanced level of an enterprise can be improved.
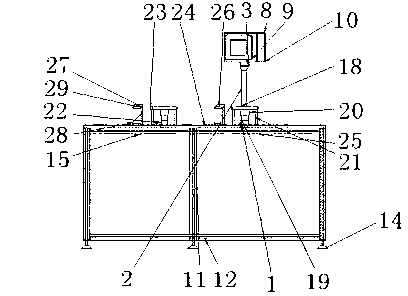
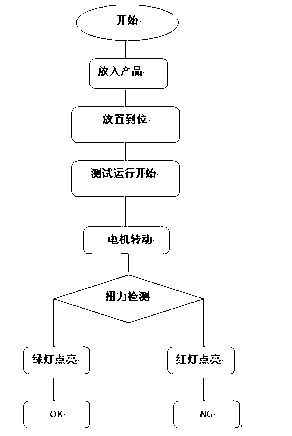
Owner:SUZHOU NETABHAPE COMPOSITE MATERIALS
Magnetostrictive torque measurement device
Provided is a magnetostrictive torque measurement device that makes it easy to ensure accuracy of torque measurement, sensitivity of torque measurement, or both. A magnetostrictive torque measurement device 1 comprises: a rotary shaft 2 that has a detected part 4 that has magnetostrictive characteristics at a portion in the axial direction of an outer circumferential surface; and a magnetostrictive torque sensor 3. The magnetostrictive torque sensor 3 includes: a holder 5 that is formed from a synthetic resin, has an inner circumferential surface 7 that is loosely fitted in the radial direction onto the outside of the detected part 4 so as not to rattle, and does not rotate even during use; and a coil unit 6 that is held by the holder 5 and has a detection part 12 that includes a plurality of detection coils 11 (11a–11d).


Owner:NSK LTD
Strain wave gearing having torque sensor
A strain wave gearing (1) is configured to have a unitized structure having a main bearing (5) that supports an internally toothed gear (2) and an externally toothed gear (3) in a manner that allows relative rotation, and an output flange (6) that is linked to the externally toothed gear (3). The externally toothed gear (3) is formed in the shape of a wine glass and ensures a large hollow diameter, which is required in cases where the externally toothed gear (3) is incorporated into a robot joint part or the like. A strain gauge (101) of a torque sensor (100) is attached to an outward-facing end surface portion of the output flange (6) linked to the externally toothed gear (3). The torque sensor (100) is capable of precisely detecting rotational torque without being affected by flexing of the externally toothed gear (3), and elements such as the strain gauge (101) are not exposed to oil, grease, or the like.

Owner:HARMONIC DRIVE SYST IND CO LTD
Robot joint transparency testing method and device
The invention discloses a robot joint transparency testing method and device, and belongs to the technical field of robot joint testing. According to the method, the transmission transparency is evaluated by testing three indexes including the ratio of joint reverse drive torque to the maximum output torque, the torque control bandwidth and the correlation between motor current and output torque; the device comprises a driving mechanism, a loading mechanism and a test platform with a sliding assembly, the driving mechanism is connected with a joint input end through a coupling, and the loading mechanism is connected with an output end. According to the invention, a quantitative evaluation system of transmission transparency is established, a modular device capable of separably testing joint motor reverse drive torque (distinguishing charged / uncharged states) and speed reducer forward / reverse drive efficiency is designed, and accurate data support is provided for joint performance optimization.

Owner:GUANGDONG OCEAN UNIVERSITY
Gearbox variable working condition mechanical loss torque efficiency correction test method based on neural network
The invention provides a gearbox variable working condition mechanical loss torque efficiency correction test method based on a neural network. The method comprises the following steps: S1, determining a to-be-tested gearbox and basic parameters; s2, building a gearbox variable working condition test system; s3, acquiring basic operation data of the gearbox; s4, calculating theoretical mechanical loss torque and efficiency of the gear box; s5, the actually-measured mechanical loss torque and efficiency of the gearbox are collected, and an error data set is generated; s6, constructing and training an error correction model fusing the back propagation neural network and support vector regression; s7, performing mechanical loss torque and efficiency correction based on the fusion model; and S8, verification and feedback optimization of a correction result. According to the method, on the basis of all-working-condition data, the defect of a single model is overcome through double-algorithm fusion, precise correction of the mechanical loss torque and efficiency of the gearbox under the variable working conditions is achieved, and reliable data support is provided for gearbox design optimization, working condition matching and energy efficiency evaluation.

Owner:CIVIL AVIATION FLIGHT UNIV OF CHINA
Six-dimensional force sensor, torque force sensor and preparation method thereof
The invention relates to the technical field of sensors, and provides a six-dimensional force and torque force sensor and a preparation method thereof.The six-dimensional force sensor is of a disc-shaped structure and comprises an outer supporting ring, an inner mass block and eight elastic beams connected between the outer supporting ring and the inner mass block; wherein the eight elastic beams comprise a first elastic beam and a second elastic beam which are alternately arranged around the inner mass block, the first elastic beam is a straight beam, the second elastic beam is a special-shaped beam, and a strain gauge preset on the main surface of each elastic beam responds to the strain of the elastic beam to generate a measurement signal; and the force and / or the torque applied to the inner mass block or the outer support ring can be determined according to the measurement signal. Due to the fact that the different elastic beams are different in shape and structure, the strain gauges are preset on the elastic beams of different types and positions, and the bridging mode is set, the output of each Wheatstone bridge is only sensitive to the force or the moment of force in the changed direction and is not sensitive to the force or the moment of force applied in other directions, and the decoupling capacity of the sensor structure is improved to the maximum degree.

Owner:JINGYI MICROSENSE (SHANGHAI) TECHNOLOGY CO LTD
Combined three-dimensional force / torque sensor and miniature calibration system thereof
PCT designated stageWO2025208666A1Work measurementApparatus for force/torque/work measurementAxial pressureCoupling
A combined three-dimensional force / torque sensor. A plurality of discrete one-dimensional force sensors (11, 12, 13, 14) are used to measure force components, and a conduction flange (2) is used to transmit an external force. The combined design effectively reduces inter-dimensional coupling and has a simple structure. The lateral torque and the axial pressure are monitored in a differential form and a summation form, thereby effectively improving the sensitivity and measurement accuracy of the sensor. Further disclosed is a miniature calibration system established by using the combined three-dimensional force / torque sensor. The calibration system has a small size and a simple structure, is easy to assemble and convenient to carry and transfer, and is capable of on-site calibration.

Owner:SOUTHEAST UNIV
Magnetostrictive torque sensor
A magnetostrictive torque sensor for measuring torque that is applied to a rotating shaft having magnetostrictive characteristics, includes a flexible substrate having a plate-shaped base material made of a flexible dielectric material and a plurality of detection coils formed by conductor patterns on front and back sides of the base material, and a measurement unit that measures the torque by the change in inductance of the plurality of detection coils due to the change in magnetic permeability of the rotating shaft, wherein the plurality of detection coils includes a first detection coil comprising a first coil winding including a first inclined portion inclined to one side with respect to an axial direction of the rotating shaft, and a second detection coil comprising a second coil winding including a second inclined portion inclined to the other side with respect to the axial direction of the rotating shaft, wherein the flexible substrate includes parallel extending portions where the first coil winding and the second coil winding extend parallel to sandwich the substrate, and wherein a centerline of the first coil winding and a centerline of the second coil winding are misaligned in a direction perpendicular to their respective centerlines in the parallel extending portions.

Owner:PROTERIAL LTD
Power control actuator
A power control actuator of the present disclosure includes: an output-side bearing provided on a side on which a torque is to be outputted; a speed reducer including an output shaft; and a torque sensor that detects a torque associated with rotation of the output shaft, in which an outer peripheral surface of the torque sensor and an inner peripheral surface of the output-side bearing constitute a spigot joint structure, an inner peripheral surface of the torque sensor and an outer peripheral surface of the output shaft of the speed reducer constitute a spigot joint structure, and the output-side bearing, the output shaft of the speed reducer, and the torque sensor have a coaxial structure.

Owner:SONY GROUP CORP
Digital monitoring system for slip form construction of silo structure
The invention discloses a silo structure slip form construction digital monitoring system, which comprises a monitoring module used for acquiring elevation and torsion data of a slip form platform and inclination angle data of a silo wall in real time, and a data acquisition and forwarding module used for acquiring and forwarding monitoring data of the monitoring module, the data analysis processing module is used for receiving monitoring data, and the user side module is used for receiving difference adjustment information output by the data analysis processing module, generating a monitoring curve and a report form according to the difference adjustment information and visualizing the monitoring curve and the report form. The monitoring module comprises a slip form platform elevation monitoring assembly, a slip form platform torsion monitoring assembly and a silo wall inclination angle monitoring assembly. The detection system can automatically monitor the elevation of the slip form platform, the inclination angle of the silo wall and the torsion of the slip form platform in real time in the construction process of the silo structure at the same time, report and curve visualization is carried out on detection results, the construction process of the slip form is guided, the construction efficiency of the slip form is improved, and safety accidents can be avoided.

Owner:SHAANXI SHAANXI COAL HANCHENG MINING CO LTD
Cutter wear monitoring method based on physical guidance dynamic gating chart convolution framework
PendingCN121093301ASubsonic/sonic/ultrasonic wave measurementWork measurementCorrelation coefficientFeature set
The invention discloses a cutter wear monitoring method based on a physical guidance dynamic gating chart convolution framework, and the method comprises the steps: 1, collecting a cutting force signal, a bending moment signal and a vibration signal of a cutter and a workpiece in the operation process of the cutter; 2, performing data preprocessing on the acquired multi-source sensor signal sequence; 3, calculating a Pearson correlation coefficient between each feature in the original feature set and the tool wear; 4, screening the first Top-k features to construct a sensitive feature set integrating force, vibration and bending moment; 5, extracting cutter wear information in the sensitive feature set by adopting a dynamic gated graph convolutional network, and establishing long-term dependency between features; and 6, performing output decoding on the features after the long-term dependency is established, establishing a mapping relation between the tool wear value and the input features, and outputting a tool wear monitoring value. According to the method, deep fusion of the graph structure and the time sequence features is realized, and the accuracy and stability of tool wear prediction are effectively enhanced.

Owner:CHONGQING UNIV +1
Preparation and installation method of film strain sensor and harmonic reducer
The invention relates to the technical field of film strain, in particular to a preparation and installation method of a film strain sensor and a harmonic reducer. The preparation and installation method comprises the steps that the surface of a workpiece to be installed is coated with a polyamide acid solution, then heating is conducted, and polyamide acid is subjected to dehydration cyclization to form a polyimide film attached to the surface of the workpiece to be installed; and then, forming a laser-induced graphene electrode pattern on the polyimide film. The harmonic reducer comprises a wave generator, a rigid gear, a flexible gear and a thin film strain sensor, the flexible gear is connected into the rigid gear in a toothed mode, and the wave generator is arranged in the flexible gear; the film strain sensor comprises a strain film and a graphene electrode, the graphene electrode is formed on the strain film, and the strain film is in direct contact connection with the surface of the flexible gear. Through the film strain sensor adhered to the surface of the workpiece to be installed, in-situ torque detection can be achieved, measurement errors, hysteresis, instability and the like caused by a glue joint layer are avoided, and measurement is more accurate.

Owner:GREE ELECTRIC APPLIANCE INC OF ZHUHAI
Nut locking torque measuring device and measuring method
InactiveCN120800639AMeasurement of torque/twisting force while tighteningWork measurementTorque wrench
The invention discloses a nut locking torque measuring device and method, and the device comprises a bottom plate, a torque measuring assembly, a clamping assembly, a one-way locking assembly and a driving assembly, the top of the torque measuring assembly is provided with a measuring end, the measuring end is detachably connected with a mounting part, and the clamping assembly comprises a mounting seat. Two clamping parts which are oppositely arranged are movably connected to the mounting seat, clamping surfaces are arranged on the two clamping parts, limiting blocks are arranged on the two clamping surfaces, the two sets of one-way locking assemblies are arranged on the mounting seat and used for locking the two clamping parts respectively, and the driving assembly is movably connected with the mounting seat. A first elastic piece is arranged between the driving assembly and the mounting base, and the driving assembly is used for driving the mounting base to move in the vertical direction and driving the mounting base to rotate. The torque wrench aims at solving the technical problems that a torque wrench is narrow in application range, high in cost and inconvenient to align and operate.

Owner:YANCHENG XINXING PRECISION MASCH TECH CO LTD
Portable on-vehicle dynamometer
A portable on-vehicle dynamometer comprises a containment chassis (2), a drum (3) rotatably housed in said containment chassis (2) to rotate around a load shaft (4), mechanical transmission means (5) adapted to connect said load shaft (4) to the hub of a wheel of the vehicle being measured to transfer the motion of the vehicle engine to said drum (3), wherein said mechanical transmission means (5) comprise a connection flange (6) provided with a central axis of rotation and suitable to be fixed stably but removably to the hub of the vehicle wheel, wherein said mechanical transmission means (5) further comprise a CV joint (7) adapted to connect said flange (6) with one end of said load shaft (4) and designed to allow mutual angular regulation between said load shaft (4) and the central rotation axis of said flange (6) with respect to at least one inclination plane.

Owner:MAGIC ENGINEERING SRL
Method and system for acquiring output power of turbine
The invention discloses a method and a system for acquiring the output power of a turbine, relates to the technical field of turbine monitoring, and provides a five-stage closed loop aiming at a ship high-temperature wet vibration environment, and millisecond-stage alignment torque, rotating speed, fuel oil, exhaust and vibration signals are synchronously acquired in a multi-source manner; secondly, a credibility matrix is constructed through null drift detection, wavelet denoising and consistency verification, and initial power is obtained through Kalman fusion; performing real-time comparison by using a digital twinborn model, and adaptively adjusting the weight of the sensor to output a correction power curve; then decomposing the virtual-real residual into slow drift, transient and harmonic factors, and dynamically modifying the sensitivity and the sampling rate to realize source end self-compensation; and finally, performing windowed compression, partitioning and salting hash on the correction curve, quickly confirming the right of the three-node lightweight block chain, and writing the fingerprint back to a twin model to realize minute-level tamper-proof traceability. The method has the advantages of high-resolution measurement, rapid deviation correction and real-time credible evidence storage.

Owner:GUANGDONG OCEAN UNIVERSITY
Strain-generating structure and force sensor
Disclosed is a strain-generating structure and a force sensor. The strain-generating structure comprises at least one strain body configured to generate strain under an external force. A surface of the at least one strain body is provided with at least one concave-convex structure. The at least one concave-convex structure is provided with a concave portion and a convex portion adjacent to the concave portion. The convex portion of the at least one concave-convex structure is provided with at least one strain gauge. The at least one strain gauge is configured to sense the strain. The strain-generating structure has a datum plane perpendicular to an axis of the strain-generating structure. Each of the at least one strain gauge is disposed parallel to the datum plane. The strain-generating structure attaches the strain gauges to a plane that facilitates operation of the machine and considers the detection performance of a six-axis force / torque sensor.

Owner:SUZHOU SAC AUTOMOTIVE TECHNOLOGY CO LTD
Cam indicator and detection method
The invention discloses a cam indicator and a detection method. The cam indicator comprises a tensioning seat mechanism, a lifting mechanism and a cam mechanism which are arranged on a rack from top to bottom. The tensioning seat mechanism comprises a tensioning seat and a positioning head, wherein the tensioning seat is arranged at the upper end of the rack in a vertically movable mode, the positioning head is arranged on the tensioning seat, and a pressure sensor is arranged at the position, close to the positioning head, in the tensioning seat. The lifting mechanism comprises a lifting seat which is arranged on the rack in a manner of moving up and down, and a displacement sensor is arranged in the rack close to the lifting seat; the cam mechanism can drive the lifting seat to move back and forth in the vertical direction; the provided cam indicator can effectively simulate the real working condition of the shock absorber, can effectively collect displacement and pressure data, can effectively adjust simulation according to the sizes of shock absorbers of different models, and can adjust the displacement distance according to detection requirements.

Owner:WUHU YAOGUANG INTELLIGENT EQUIP CO LTD
Strain wave gear mechanism
The invention relates to a strain wave gear mechanism comprising: a wave generator which is rotatably mounted relative to a flexspline about an axis of rotation; and a gear which meshes with the flexspline. The problem is solved by a strain wave gear mechanism which is characterised by: at least one deformation measurement sensor which measures a deformation, in particular a radial deformation, of the gear and / or of a transmission component which is connected to the gear or to the flexspline, said deformation being caused by the shape of the wave generator; and an evaluation device which receives measurement signals from the at least one deformation measurement sensor and, on the basis of the measurement signals, determines the rotational position and / or the rotational speed and / or the direction of rotation of the wave generator and / or of a transmission element rotating in accordance with the reduction ratio of the strain wave gear mechanism, in particular of the flexspline, in particular relative to the gear or relative to the flexspline.

Owner:OVALO
Testing device for underground sealing element
PendingCN121163847AWork measurementMachine sealing rings testingThermodynamicsMechanical engineering
The invention provides a testing device for an underground sealing element. The testing device comprises a detection part and an input part, a sealing cavity used for simulating the underground environment is formed in the detection part, and an assembling cavity used for assembling a sealing piece and a detection cavity used for detecting leakage are further formed in the detection part. Before the sealing element is assembled, the sealing cavity is communicated with the detection cavity through the assembling cavity. After the sealing element is assembled, the sealing cavity and the detection cavity are separated by the sealing element. The detection part can drive the sealing element to rotate so as to measure the torque of the sealing element. The output end of the input part communicates with the sealing cavity, and slurry under the preset pressure and the preset temperature can be conveyed into the sealing cavity through the input part so as to control the pressure and the temperature of the sealing cavity. And the detection part can also detect the existence condition of slurry in the detection cavity so as to measure the failure leakage condition of the sealing element. The underground environment and the working state of the sealing element can be simulated, so that a large amount of experimental data can be obtained, and the usable time of the sealing element can be accurately mastered in advance.

Owner:CHINA NAT PETROLEUM CORP +2
Rolling bearing friction torque testing device
The utility model relates to a rolling bearing friction torque testing device which comprises a driving unit, a diaphragm coupling, a supporting shaft system, a heating ring, a high-low temperature box heat preservation sleeve, a high-low temperature box, a test bearing friction torque testing assembly and a rack. The test bearing friction torque test assembly comprises a test bearing outer bush, a test bearing, a test connecting shaft, a test bearing inner ring gland, a test bearing outer ring gland, a guide rod, a miniature force sensor, a force sensor fixing frame and a high and low temperature box base. The friction torque testing device is ingenious in design, simple in structure, convenient and practical, can simulate testing of starting friction torque and operation friction torque of the rolling bearing in high and low temperature environments, fills the blank of friction torque measurement of the rolling bearing in the high and low temperature environments in the bearing industry, enhances testing technical means and methods of the rolling bearing in high and low temperature aspects, and improves testing efficiency. Compared with the prior art, the device has good market prospect and development space.

Owner:LUOYANG BEARING RES INST CO LTD +1
Method and system for dynamically detecting torque of pitching transmission shaft of figure rocket launcher
The invention discloses a figure rocket launcher pitching transmission shaft torque dynamic detection method and system, and the method comprises the steps: enabling a stepping motor to drive a driving gear through a speed reducer to drive a pitching transmission shaft to rotate, and collecting a torque signal in real time through a magnetoelectric induction torque sensor; and the phase difference measuring unit converts the dual-channel sinusoidal signal into a square wave and calculates the phase difference, and then outputs a digital torque value through the analog-to-digital converter. And the control module adopts Kalman filtering and a calibration curve to realize dynamic compensation. The recording sub-module is provided with a high-capacity solid-state memory and supports continuous recording of detection data in a circulating storage mode. The differential sensing structure is adopted, the neodymium iron boron magnetic steel and the multi-layer winding signal coil design are combined, the detection precision of the micro torque fluctuation under the low-speed and heavy-load working condition is effectively improved, the technical problems of detection lag, transient impact missing detection, data tracing difficulty and the like existing in a traditional method are solved, and the detection precision of the micro torque fluctuation under the low-speed and heavy-load working condition is improved. And the safety monitoring capability of the rocket launcher transmission system is obviously enhanced.

Owner:CHENGDU ZHENGYANG BOCHUANG ELECTRONICS TECH
Method for accurately determining output torque and collaborative robot
The present invention relates to a method for accurately determining an output torque, in particular an output torque of an actuator gear mechanism of a joint of a collaborative robot, by an artificial intelligence designed to output one or more output variables based on input variables, wherein the input variables of the artificial intelligence include a first angle specification corresponding to an input angular position and a second angle specification corresponding to an output angular position, and further wherein the output variables include an output torque determined by the artificial intelligence.

Owner:SCHAEFFLER TECHNOLOGIES AG & CO KG
Integrated strain type torque sensor based on harmonic reducer
The invention discloses a harmonic reducer integration-based strain torque sensor, and relates to the technical field of sensors, the harmonic reducer integration-based strain torque sensor comprises an annular strain gauge and a signal acquisition module, and the annular strain gauge is electrically connected with the signal acquisition module; the annular strain gauge is mounted on the bottom surface of the flexible gear and is concentric with the flexible gear; the signal acquisition module is mounted outside the hollow inner shaft of the flexible gear; during working, when output power of the flexible gear is subjected to resistance, the bottom surface of the flexible gear generates strain, the annular strain gauge converts a strain signal into an analog voltage signal through a Wheatstone bridge formed by a resistance wire grid, the analog voltage signal is output to the signal acquisition module, and a force value signal is obtained after digital-to-analog conversion; by arranging the annular strain gauge on the bottom surface of the flexible gear, real-time detection of output torque is realized, extra flexible introduction of deformation of the peripheral surface of the flexible gear is avoided, structural deformation is reduced, interference of rotation of a wave generator on signals is effectively suppressed through a Wheatstone bridge design, and measurement precision and stability are ensured.

Owner:上海安培龙科技有限公司
Electronic Torque Wrench with Automatic Moment Arm Length Determination
A method is provided for determining a torque value of a torque applied by an electronic torque wrench that includes a handle, a square drive and a strain gauge. The method includes measuring an angular velocity and a normal acceleration of the handle as the handle is rotated relative to the square drive, and finding a length of a moment arm from the square drive to the handle based on the angular velocity and the normal acceleration. The method includes measuring a bending moment of a rotational force at the strain gauge that is located at a known distance from the handle, the bending moment measured as the rotational force is applied at the handle that produces the torque at the square drive. And the torque value is determined based on the bending moment, the length of the moment arm and the known distance.

Owner:APEX BRANDS INC
Sensor device, torque sensor device, magnetic sensor module
This sensor device comprises a sensor body (13 to 16, 21, 22), a sensor housing (30), a connector housing (50), and a flange 51. The sensor body (13 to 16, 21, 22) captures changes in a physical quantity, and the sensor housing (30) accommodates at least a portion of the sensor body. The connector housing (50) is provided with a detecting element (40) that outputs a signal corresponding to a change in the physical quantity, and the part in which the detecting element (40) is provided is inserted inside the sensor housing (30). The flange (51) extends outward from the connector housing (50), and a joining surface (53) facing the sensor housing (30) side is joined to the sensor housing (30). The joint surface (53) of the flange (51) is inclined with respect to a virtual plane (VS) that is perpendicular to a direction (ID) in which the part of the connector housing (50) in which the detecting element (40) is provided is inserted into the sensor housing (30).


Owner:DENSO CORP
Sensing device
ActiveUS12442661B2Work measurementAutomatic steering controlClassical mechanicsMechanical engineering
An embodiment may provide a sensing device comprising: a rotor; a stator arranged to correspond to the rotor; and a first collector arranged on the upper side of the stator and a second collector arranged on the lower side of the stator, wherein the first collector comprises a first unit collector including a first plate and a first leg, and a second unit collector including a second plate and a second leg. The second collector comprises a third unit collector including a third plate and a third leg, and a fourth unit collector including a fourth plate and a fourth leg. The first plate and the second plate are spaced apart from each other, and the third plate and the fourth plate are spaced apart from each other.

Owner:LG INNOTEK CO LTD
Tool for testing friction torque performance of ball screw supporting bearing
The invention discloses a ball screw support bearing friction torque performance test tool, which relates to the technical field of friction torque detection and comprises a base platform, a bearing clamping mechanism and a torque detection mechanism. The base platform is provided with a test workbench, the bearing clamping mechanism is fixed on the workbench, the torque detection mechanism comprises a vertical adjustment unit, a driving sensing part and an inner ring locking clamp, and the vertical adjustment unit controls the vertical displacement of the driving sensing part and the inner ring locking clamp; and the driving sensing part drives the bearing inner ring to rotate through a motor and detects the dynamic friction torque. The problems that in the prior art, due to the high starting torque caused by the time-varying characteristic of lubricating grease, an overload phenomenon is likely to happen to a detection system when a high-precision sensor conducts detection are solved. The method has the advantages that overload protection is started through the preset threshold value, the high-precision torque sensor is prevented from being damaged by the low-temperature starting torque peak value, and meanwhile the overtravel torque value is quantified synchronously.

Owner:CSC BEARING
Quantitative testing method and system for peak locked-rotor torque of robot joint module
The invention discloses a quantitative test method and system for a peak locked-rotor torque of a robot joint module, and relates to the technical field of robot joint performance evaluation, and the method comprises the steps: extracting a torque time-calendar curve of the joint module, defining the peak locked-rotor torque as a controlled low-frequency fatigue loading process, and building a mapping model of a torque amplitude and a failure cycle index; constructing a test system, and performing torque-current static calibration; embedding a specific excitation function in a current loop of the servo driver; the bus voltage and rotating speed change rate is monitored in real time, and the voltage and current impact at the unloading moment is inhibited by adopting a back electromotive force compensation algorithm and combining an energy consumption discharge loop; and repeatedly loading until the structure is damaged, recording the number of cycles, and drawing a peak torque-life curve as a basis for predicting the life of the whole machine. According to the method, quantitative association of the peak locked-rotor torque and the fatigue life is realized, quantitative evaluation from a static index to a dynamic life is realized, a basis is provided for life prediction of the whole robot, and the test precision is improved.


Owner:LUMING ROBOT TECHNOLOGY (SHENZHEN) CO LTD
Vertical loading nut main transmission lead screw pair transmission efficiency testing method, system and device
The invention discloses a method, system and device for testing the transmission efficiency of a nut main transmission lead screw pair with vertical loading, and the method comprises the steps: installing the nut main transmission lead screw pair on a vertical power transmission path, fixing a lead screw, and enabling a nut to carry out the axial movement while achieving the rotation movement; a displaceable torque conduction module is additionally arranged between the output end of the motor and the nut, so that torque is continuously input in real time while the nut moves axially; a loading module is arranged to apply a dynamic or static load to the nut so as to simulate actual loads under different working conditions; the input torque, the nut rotating speed, the axial load and the displacement of the nut main transmission lead screw pair are detected in real time; based on real-time detection data, the transmission efficiency eta is calculated, and a real-time efficiency curve is generated. Based on a vertical structure, a test scheme of complete fixation of the lead screw and composite motion of rotation and axial movement of the nut is innovatively adopted, the problem of motion limitation of a long nut structure in a nut main transmission lead screw pair is effectively solved, and meanwhile, the influence of additional bending moment generated by a cantilever structure on the measurement precision in a traditional test is eliminated; and the accuracy and reliability of the transmission efficiency test of the nut main transmission lead screw pair are obviously improved.

Owner:NANJING UNIV OF SCI & TECH