

Patents
Literature
50results about How to "Guaranteed global consistency" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Mobile robot cascading map building method based on remarkable scenic spot detection
InactiveCN103278170ARealize online creationSolve the key problems of automatic segmentationInstruments for road network navigationImage analysisComputer scienceMobile robot navigation
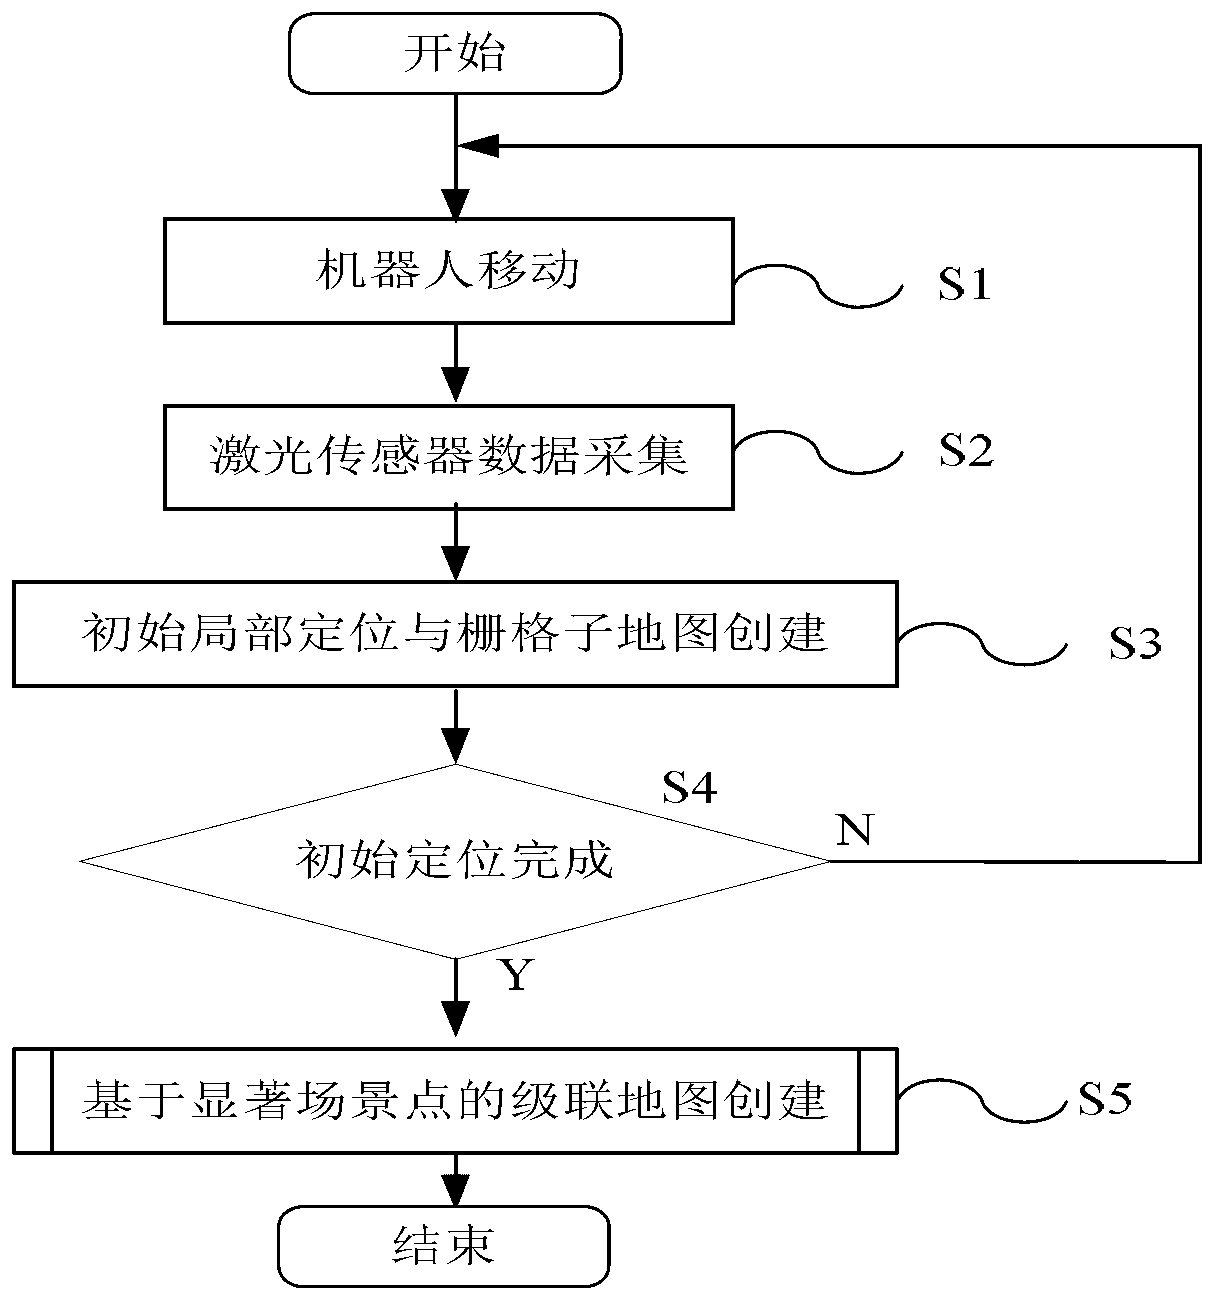
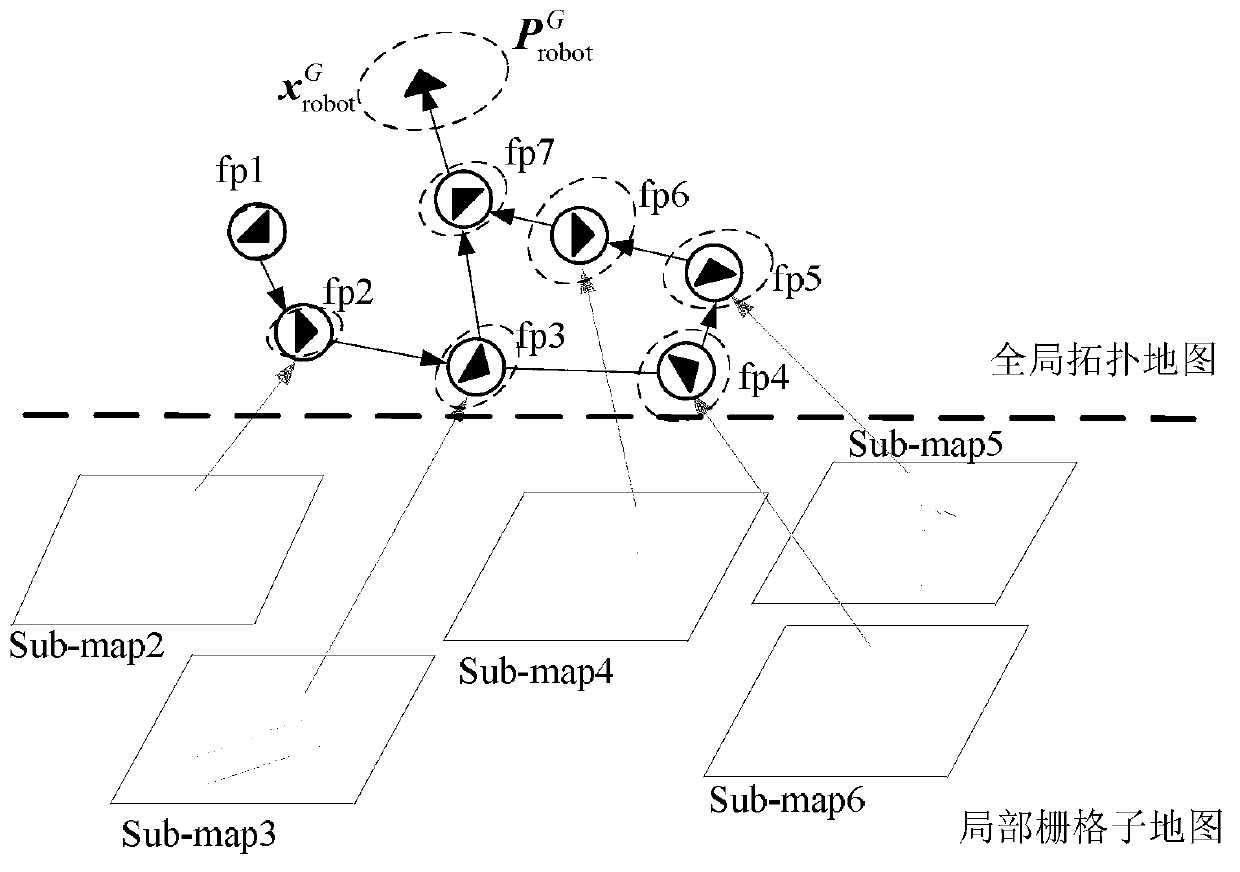
The invention relates to the technical field of mobile robot navigation and discloses a mobile robot cascading map building method based on remarkable scenic spot detection. The mobile robot cascading map building method comprises the steps of: 1) according to image data collected by a mobile robot sensor, carrying out on-line detection on a road sign of a natural scene corresponding to a remarkable scene so as to generate a topological node in a global map; 2) updating the pose of a mobile robot and a local grid map; and 3) building a global topological map structure by taking a remarkable scenic spot as the topological node, and optimizing the topological structure by introducing a weighted scanning and matching method and a relaxation method on the basis of the closed detection of trajectory of the robot to ensure the global consistency of the topological map. The mobile robot cascading map building method is applicable to the autonomous path planning and navigation application for various mobile robots in large indoor environment ranges such as a plurality of rooms and corridors.
Owner:SOUTHEAST UNIV
Unmanned aerial vehicle scene dense reconstruction method based on VI-SLAM and depth estimation network
ActiveCN112435325ACalculation speedEliminate cumulative errorsImage analysisInternal combustion piston enginesPoint cloudUncrewed vehicle
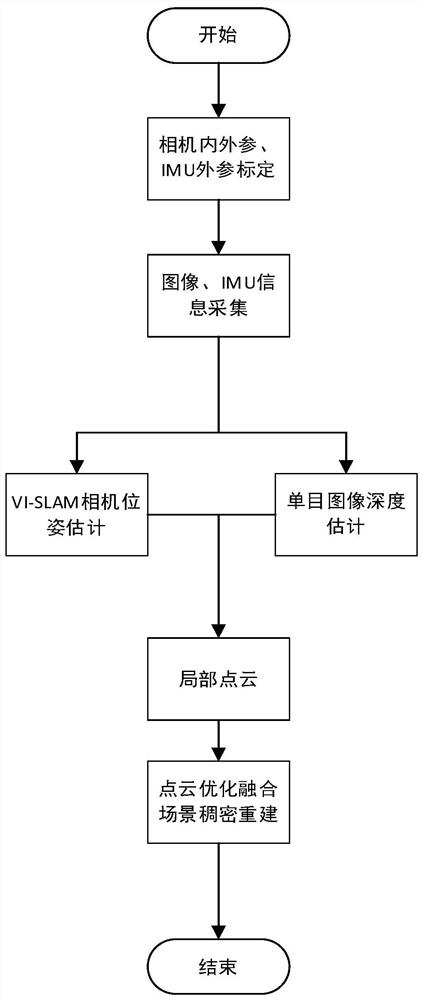
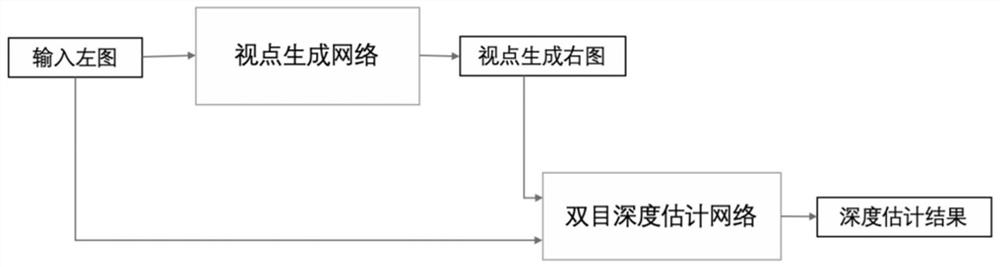
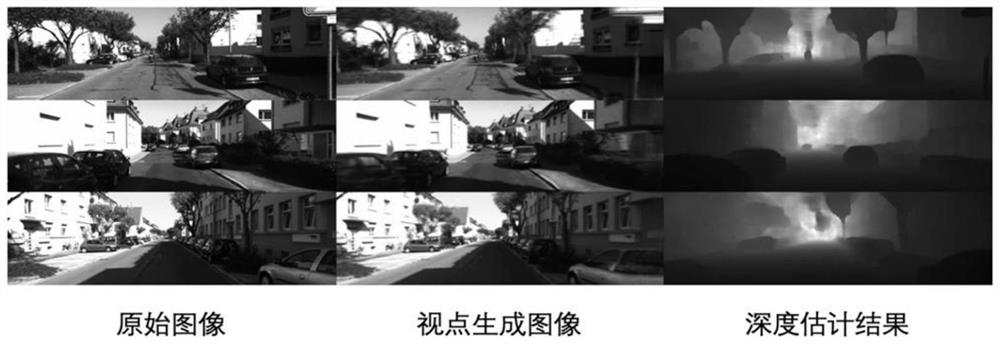
The invention relates to an unmanned aerial vehicle scene dense reconstruction method based on VISLAM and depth estimation, and the method comprises the steps: (1) fixing an inertial navigation unit IMU to an unmanned aerial vehicle, and calibrating the internal parameters and external parameters of a monocular camera of the unmanned aerial vehicle and the external parameters of the IMU; (2) collecting an image sequence and IMU information of an unmanned aerial vehicle scene by using an unmanned aerial vehicle monocular camera and an IMU; (3) processing the image and the IMU information acquired in the step (2) by using VISLAM to obtain a camera pose with scale information; (4) inputting the monocular image information as an original view into a viewpoint generation network to obtain a right view, and inputting the original view and the right view into a depth estimation network to obtain depth information of the image; (5) combining the camera attitude obtained in the step (3) with the depth map obtained in the step (4) to obtain a local point cloud; and (6) through point cloud optimization and registration, fusing the SLAM tracking trajectory with the local point cloud to obtainan unmanned aerial vehicle scene dense point cloud model.
Owner:BEIHANG UNIV
360-degree real-time three-dimensional reconstruction method for an object based on a consumption-level color depth camera
ActiveCN109242873AGuaranteed 360-degree scan reconstructionReduce the impact of rebuildingImage analysis3D modellingObject basedFixed frame
The invention discloses a 360-degree real-time three-dimensional reconstruction method for an object based on a consumption-level color depth camera, belonging to the three-dimensional reconstructionfield, comprising the following steps: (1) automatically segmenting a target object as an initial object frame to start a scanning and reconstruction process of the target object; (2) tracking the object frame frame by frame to extract the depth data of the object; 3) carrying out local fusion on that depth data of a fixed frame object, registering all the partially fuse model segments into a global non-rigid body at intervals of fixed frames, and constructing a consistent global three-dimensional model; 4) after that partial scanning is completed, continuously scanning the flipped object, andestimating the camera posture change before and after the flip; 5) After 360-degree reconstruction, aligning all the color images of key frames with the model, and calculating texture mapping for themodel. The invention has the characteristics of fast reconstruction of a 360-degree model, robust results and high texture mapping quality.


Owner:ZHEJIANG UNIV
Method and system for concurrency control
InactiveCN102122288AGuaranteed global consistencySpecial data processing applicationsConcurrency controlDeadlock
The invention discloses a method and system for concurrency control, belonging to the field of computers. The method comprises the following steps: receiving a global transaction by an initial storage server, and dividing the global transaction into a plurality of sub-transactions; if a write-operation sub-transaction exists in the sub-transactions, selecting a first number of copy storage servers by the initial storage server, and sending a locking request to each selected copy storage server; receiving the locking request by each selected copy storage server; if the locking request is permitted, sending a response message to the initial storage server; receiving the response message by the initial storage server; and sending the specific operation information of the write-operation sub-transaction to the copy storage server which sends the response message if the response messages of the second number are received. The system comprises the initial storage server and the copy storage server. According to the invention, the phenomenon of deadlock can be avoided, and the global consistency is guaranteed.


Owner:北京高森明晨信息科技有限公司
Data synchronization method in distributed equipment according to address resolution protocol
ActiveCN1874310AGuaranteed global consistencyAvoid sync failuresData switching networksData synchronizationAddress Resolution Protocol
The apparatus thereof comprises a main control module and a distributing module. The method thereof includes: a) said distributing module reports a message not capable of routing by itself to said main control module; b) in term of said message, the main control module looks up ARP table; if a corresponding list item is found, and then synchronizing ARP data with said distributing module. The invention can make ARP data in distributing equipment keep global consistency. Besides, the invention determines the consistency of ARP data based on the message forwarding state so as to avoid loss of synchronization data or synchronization failure caused by adding ARP list item using software.


Owner:NEW H3C TECH CO LTD
Aviation video stream target identification processing method and system
ActiveCN119151984Aimprove accuracyImprove robustnessImage enhancementImage analysisAviationImage manipulation
The invention provides an aviation video stream target identification processing method and system, relates to the technical field of image processing, artificial intelligence and aviation monitoring, and aims to realize the target identification processing of an aviation video stream through preprocessing modal data such as video, infrared and radar and combining an adaptive weighted fusion technology, a multi-stage visual feature extraction and a global convolution optimization technology. The system can extract target features from multi-level and multi-modal data; and a historical motion track and future motion prediction are further combined, the system dynamically corrects the target position, and finally the consistency of multi-modal data is ensured through cross validation. According to the method, the recognition precision and robustness of the system to weak and small targets are enhanced, missing detection and false detection are reduced, the adaptability is high, the requirement for computing resources is low, and the method is suitable for target recognition and tracking tasks in a complex dynamic environment.

Owner:HUNAN TUXING INTELLIGENT TECH CO LTD
Method and device for constructing topographic map based on multi-quadrangle mesh
ActiveCN106251400AEfficient removalGuaranteed global consistency3D modellingViewpointsImage resolution
The invention discloses a method and a device for constructing a topographic map based on a multi-quadrangle mesh. The method comprises the following steps: constructing a multi-quadrangle base mesh body composed of multiple quadrilateral surface patches according to topographic space data, and determining the adjacency information of each quadrilateral surface patch; selecting effective quadrilateral surface patches according to viewpoint parameters and a default resolution, wherein the effective quadrilateral surface patches are quadrilateral surface patches in a visible area of the multi-quadrangle base mesh body; triangularizing the effective quadrilateral surface patches in sequence, segmenting the effective quadrilateral surface patches into multiple triangular sub-patches, and determining the adjacency information of each triangular sub-patch; and performing combination according to the adjacency information of the effective quadrilateral surface patches and the adjacency information of the triangular sub-patches, and determining a combined topographic map. Global triangularization is performed by recording global adjacency information, seams are removed effectively during triangularized combination, the global consistency of mesh triangularization between surface patches is ensured, and extra seam sewing operation is avoided.


Owner:中国人民解放军63920部队
Automatic operation and maintenance management system and method
ActiveCN111193602AReduce complexitySolve the problem that requires multiple operation and maintenance platformsData switching networksWeb applicationMaintenance management
The invention discloses an automatic operation and maintenance management system and method. The system comprises a Web application server configured to receive an operation and maintenance operationinstruction and determine an agent device based on the operation and maintenance operation instruction; a proxy device which is configured to receive the operation and maintenance operation instruction from the Web application server and establish a standardized protocol channel between the proxy device and at least one managed device corresponding to the operation and maintenance operation instruction according to the operation and maintenance operation instruction, and the standardized protocol channel refers to processing input and output formats of the protocol channel according to standardized requirements; and at least one managed device, wherein the managed device comprising pre-configured user information and a script client, the managed device being configured to receive an operation and maintenance operation instruction through the standardized protocol channel and execute the operation and maintenance operation instruction to generate a running result. According to the technical scheme of the embodiment of the invention, through the standardized protocol channel and the managed device subjected to standardized processing, the operation process is simplified, and the complexity of operation and maintenance management is reduced.


Owner:SF TECH
Lightweight underwater image enhancement method based on adaptive feature fusion
PendingCN119540109AEnhance expressive abilityrich in detailsImage enhancementCharacter and pattern recognitionPattern recognitionQuality of vision
The invention provides a lightweight underwater image enhancement method based on adaptive feature fusion, and the method comprises the steps: decomposing an underwater image enhancement task into a strong prior enhancement task and a fine-grained enhancement task through employing a lightweight underwater image enhancement network based on adaptive feature fusion, so as to make full use of the multi-scale information in an image; the strong prior enhancement task is used for extracting global and low-layer features of the image; the fine-grained enhancement task is used for improving local details and color recovery of the image so as to improve the visual quality; the lightweight underwater image enhancement network comprises a multi-scale feature aggregation module and a global channel attention module, the multi-scale feature aggregation module is composed of an adaptive feature fusion module and a segmented convolution feed-forward network, and the lightweight underwater image enhancement network is used for combining global and local information of features and adaptively adjusting importance of each channel through information association between channels.

Owner:MINJIANG UNIVERSITY
Fine-grained large model illusion processing method and system based on zero resource framework
ActiveCN119670760AReduce development costsImprove applicabilitySemantic analysisLinguistic modelAlgorithm
The invention belongs to the technical field of natural language processing. According to the zero resource framework-based fine-grained large model illusion processing method and system, multi-dimensional anomaly detection is carried out on a preprocessed text through a large language model, and a multi-dimensional anomaly detection result is obtained; performing anomaly correction priority ranking according to a multi-dimensional anomaly detection result; dynamically adjusting a context window range according to a syntactic analysis result and the generated syntactic dependency tree; performing priority correction on high-risk vocabularies and sentences according to an abnormal correction priority ranking result in combination with the adjusted context window range; and evaluating the corrected content, and obtaining a corrected final text when a termination condition is met. According to the method, the excessive confidence, subtle semantics and grammar deviation illusion detection of the detection content is realized, and the illusion detection processing capability of a large language model, especially the detection processing capability of a fine-grained illusion problem, is improved.

Owner:SHANDONG COMP SCI CENTNAT SUPERCOMP CENT IN JINAN +3
Three-dimensional model total segmentation method for sparse low-rank feature expression
ActiveCN106204749AGuaranteed global consistencyMaintain individualityImage analysisDetails involving 3D image dataFeature vectorEuclidean vector
The invention provides a three-dimensional model total segmentation method for sparse low-rank feature expression. The three-dimensional model total segmentation method includes the steps of pre-segmenting three-dimensional models in the three-dimensional model category to obtain three-dimensional model patch blocks of each three-dimensional model; conducting histogram construction of the three-dimensional model patch blocks of each three-dimensional model to obtain feature vectors of the patch blocks of each three-dimensional model; conducting sparse low rank expression processing for the feature vectors of the patch blocks of each three-dimensional model to obtain an expression coefficient and an expression error of each three-dimensional model; determining, according to the expression coefficient and the expression error of each three-dimensional model, a trust expression coefficient of each three-dimensional model; and clustering the trust expression coefficient of each three-dimensional model and total segmenting each three-dimensional model. The global consistency of the 3D model of the same type is maintained and the individual features of each individual 3D model are maintained. The multiple expression results are correctly combined and the correctness of the three-dimensional model total segmentation results is relatively high.


Owner:BEIHANG UNIV
Human body posture editing method in image
ActiveCN106228590AEasy to operateGuaranteed global consistencyEditing/combining figures or textComputer animationHuman body
The invention discloses a human body posture editing method in an image. The human body posture editing method comprises following steps of: firstly, adopting an image segmentation method to calculate a human body silhouette and an image background in the image; secondly, adopting a silhouette profile projection method to obtain original shape parameters of a human body by use of original posture parameters of the human body obtained through calculation by using a model optimization-based human body posture identification method; thirdly, adopting a sketching interaction method to edit the original posture parameters and shape parameters so as to obtain edited posture parameters and the shape parameters; fourthly, adopting an image shape change method based on the least square method to generate a new silhouette; and finally, adopting an image synthesis method based on textures to generated an edited image. By use of the human body posture editing method, edition of human body postures in the image can be realized, the human body posture editing method is advantaged by simple operation, real effects and the like, is capable of effectively overcoming problems of inconsistent overall situations and warped backgrounds existing in a traditional image editing tool and has a wide application prospect in the field of plane design, multimedia manufacturing, computer cartoons and the like.


Owner:THE 28TH RES INST OF CHINA ELECTRONICS TECH GROUP CORP
Generative adversarial network training method, image completion method, equipment and storage medium
ActiveCN110210514AGuarantee authenticityMaintain local consistencyCharacter and pattern recognitionDiscriminatorGenerative adversarial network
The embodiment of the invention provides a generative adversarial network training method, an image completion method, equipment and a storage medium. In some exemplary embodiments of the present application, firstly, image completion training is performed by using a sample image including a missing region to obtain a preliminary completion network and a preliminary completion image; secondly, performing discriminator training by utilizing the preliminary completion image to obtain a first local context discriminator, a second local context discriminator and a global discriminator; and finally, performing confrontation training on the primary completion network through the combination of a first local context discriminator, a second local context discriminator and a global discriminator byusing the sample image containing the missing region to obtain an image completion network, wherein the first local context discriminator maintains the local consistency of image completion, the global context discriminator maintains the global consistency of image completion, and the second local context discriminator ensures the authenticity of texture information and the consistency of a completion center area and a surrounding area.


Owner:BEIJING FORESTRY UNIVERSITY
Wire instance detection method and system based on key point matching
ActiveCN119672004Aimprove accuracyImprove reliabilityImage analysisCharacter and pattern recognition3D projectionFeature data
The invention discloses a conductor instance detection method and system based on key point matching, and the method comprises the steps: obtaining original aerial image data, generating a four-dimensional feature matrix through dynamic feature mapping and enhancement processing, obtaining three-dimensional projection feature data through projection transformation, and carrying out the feature enhancement to obtain enhanced feature data. Generating enhanced feature map data through multi-scale feature fusion; performing feature recombination on the enhanced feature map data to obtain feature matrix data, generating response matrix data through recursive decomposition and mapping, and calculating adaptive threshold data to screen key points; generating thermodynamic diagram data for the screened key point set through a multi-layer thermodynamic diagram, obtaining a spatial incidence matrix by combining spatial feature enhancement, and performing endpoint matching based on multi-dimensional constraints; and finally, through boundary feature analysis and cross-block instance matching, a global traverse map is constructed, and accurate detection of traverse instances is realized. According to the invention, the accuracy and robustness of wire detection can be effectively improved.

Owner:ZHONGKE FANGCUN ZHIWEI (NANJING) TECH CO LTD
Video plane detection method based on improved algorithm
InactiveCN103761725AGuaranteed global consistencyImprove accuracyImage analysisPattern recognitionVideo sequence
The invention relates to a video plane extraction method based on an improved algorithm. In the method, tracking of characteristic points of a given video sequence is firstly performed through a standard KLT method and obtained characteristic-point tracks are recorded; whether the tracks belong to planes corresponding to a current homography matrix is judged through calculation of a reprojection error between adjacent frames and then tracking and extraction of planes of the whole video sequence are performed; and through use of obtained plane models and homography sets corresponding to the plane models, a video can be segmented so as to obtain a final plane extraction result. The video plane extraction method based on the improved algorithm is capable of extracting planes directly from the video sequence; and the tracks are selected as operation objects so that global uniformity of the plane extraction result is ensured and test convergence speed is speeded up and test convergence accuracy is improved significantly.


Owner:陕西帮你电子科技有限公司
Semantic-driven two-dimensional animation automatic generation method
PendingCN111340920ARealize automatic generationImprove satisfactionSemantic analysisAnimationComputer animationData set
The invention discloses a semantic-driven two-dimensional animation automatic generation method, and relates to the technical field of computer animation. The method comprises the steps of establishing a two-dimensional animation material library, a training sample animation set, a training sample annotation data set, a training sample corpus set, text word segmentation, named entity recognition,a knowledge graph, syntactic feature extraction and global / local semantic feature extraction, and constructing a two-dimensional animation generator-discriminator neural network. The invention discloses a semantic-driven two-dimensional animation automatic generation method. A two-dimensional animation automatic generator for dynamically tracking global / local semantics of a text is constructd to achieve automatic generation from the text to the two-dimensional animation; according to the method, the global consistency between a dynamic scene and a role can be ensured, the rationality of the generated animation can be evaluated, and experiments show that a user has a good satisfaction degree on the automatically generated two-dimensional animation and has a good market promotion value.


Owner:长沙千博信息技术有限公司
Video generation method and device, computer equipment and storage medium
ActiveCN119211665AImprove visual qualityimprove consistencySelective content distributionImaging processingComputer graphics (images)
The invention discloses a video generation method and device, computer equipment and a storage medium, and belongs to the technical field of artificial intelligence. The method comprises the steps of inputting a to-be-processed image into an image processing model to obtain a first image feature; inputting the to-be-processed image into a global encoder to obtain a second image feature; combining the first image feature and the second image feature to obtain a combined image feature; based on the combined image features, using a first video generation model to generate an initial video corresponding to the to-be-processed image; obtaining video text description, and encoding the video text description to obtain text encoding features; and inputting the initial video and the text coding feature into a second video generation model to obtain a target video corresponding to the to-be-processed image. The invention also relates to the technical field of block chains, and the to-be-processed image is stored in a block chain network. According to the method, visual details can be reproduced, global consistency can be kept, and the visual quality and semantic consistency of the video are effectively improved.

Owner:PING AN TECH (SHENZHEN) CO LTD
Automatic auditing business process control method based on rule optimization
ActiveCN119476750Aincrease flexibilityImprove adaptabilityForecastingArtificial lifeExecution planDynamical optimization
The invention discloses an automatic auditing business process control method based on rule optimization. The method comprises the following steps: S1, generating a unified auditing data pool; s2, constructing a multi-layer rule engine, and generating an initial rule set; s3, initializing an improved bee colony optimization algorithm, and dynamically defining a search space of a population; s4, dynamically optimizing the initial rule set by using an improved bee colony optimization algorithm, adjusting a single rule parameter in a search space in a worker bee stage, selecting an optimal rule direction in an observation bee stage, and introducing collaborative bees to optimize conflicts among multiple rules, and re-initializing a low-diversity population in a reconnaissance bee stage, and generating an optimized rule set; s5, generating a rule execution plan, adjusting the node priority of the auditing process and optimizing a task path; and S6, realizing continuous optimization iteration of the rule set and the audit process path based on implementation feedback of the rule execution plan. According to the invention, the multi-layer rule engine and the improved bee colony optimization algorithm realize automatic auditing business process control.

Owner:ANHUI YUNCHANG DATA TECH CO LTD
Scene depth estimation method and device, image processing equipment and storage medium
ActiveCN119600078AImprove reconstruction effectreduce time overheadImage analysisInternal combustion piston enginesPattern recognitionVisual technology
The invention discloses a scene depth estimation method and device, image processing equipment and a storage medium, and belongs to the technical field of computer vision, and the scene depth estimation method comprises the steps: selecting a single image with shielding, reflection or perspective from a multi-view image set for depth fusion; the improved depth information is spread to other views in a re-projection mode, so that the time overhead is reduced while the reconstruction effect is improved; performing semantic division on the index image to obtain the weight of each semantic factor; the problem that feature points are difficult to match due to a special area is solved by introducing single-view depth estimation; fusing a single-view estimation result and a multi-view depth estimation result under the constraint of semantic information, and spreading the fused result to other view angles in a re-projection manner to obtain a consistent depth estimation result corresponding to the current scene; consistency estimation can be accurately carried out on the depth of each area in the scene.

Owner:HUAZHONG UNIV OF SCI & TECH
Cascade Map Creation Method for Mobile Robots Based on Salient Scene Point Detection
InactiveCN103278170BRealize online creationSolve the key problems of automatic segmentationInstruments for road network navigationImage analysisComputer scienceMobile robot navigation
The invention relates to the technical field of mobile robot navigation. The invention discloses a mobile robot cascade map creation method based on salient scene point detection. It includes the following steps: 1) Based on the image data collected by the mobile robot sensor, online detect the natural scene landmarks corresponding to the salient scenes, and generate topological nodes in the global map; 2) Update the mobile robot pose and local grid submap; 3) Based on Salient scene points are used as topological nodes to create a global topological map structure. Based on the robot trajectory closure detection, the weighted scan matching method and relaxation method are introduced to optimize the topological structure to ensure the global consistency of the topological map. The invention is suitable for autonomous path planning and navigation applications of various mobile robots in large-scale indoor environments containing multiple rooms, corridors and other areas.


Owner:SOUTHEAST UNIV
Local-to-global point cloud registration method and system based on internal and external point classification
PendingCN118941599Aachieve registrationHigh precisionImage analysisImaging processingFeature extraction
The invention belongs to the technical field of computer graphic image processing, and discloses a local-to-global point cloud registration method based on internal and external point classification. According to the method, challenges of noise, abnormal values, low overlapping rate and the like in local-to-global point cloud registration can be effectively processed through a point cloud registration network framework of internal and external point classification of deep learning; a local coordinate system is introduced before feature extraction, and symbol fuzziness of the local coordinate system is eliminated in a simple and effective mode. Local areas of key points in the source point cloud and the target point cloud can be aligned through a local reference system, so that the precision of the model is improved; a similarity matrix enhancement module is introduced, and an external storage unit is used for storing the similarity relation between a source point cloud and a target point cloud. In the training process, the initial error corresponding relation is corrected through gradient calculation and back propagation, and point cloud registration under the condition of low overlapping rate is achieved. According to the experiment of the invention, compared with the existing method, the superiority and feasibility of the method are verified by qualitative and quantitative experiment results.

Owner:NORTHWEST UNIV
Real-time map generation method, device and system and storage medium
PendingCN119540481Aaccurate identificationreduce mistakesImage enhancementImage analysisPattern recognitionImaging processing
The invention discloses a real-time map generation method, device and system and a storage medium, and relates to the technical field of image processing. The method comprises the following steps: acquiring a first image frame, and processing the first image frame based on a frame screening mechanism to obtain a second image frame; inputting the second image frame into an ORB-SLAM2 system for thread processing to obtain camera pose information, ground pose parameters and a key frame, and processing the key frame based on an inferior frame rejection mechanism to obtain a third image frame; and integrating the camera pose information, the ground pose parameters and the third image frame into a Map2Dflution mapping system for processing, and generating a real-time map. According to the method and the device, positioning or mapping errors caused by image blurring are reduced, the processing flow is simplified, the calculation complexity is reduced, the influence of inferior frames on the mapping quality is avoided, and the accuracy and the stability of a map are improved.

Owner:NORTHWESTERN POLYTECHNICAL UNIV
Co-segmentation method for 3D models with sparse low-rank feature representation
ActiveCN106204749BGuaranteed global consistencyMaintain individualityImage analysisDetails involving 3D image dataMachine learningThree dimensional model
The present invention provides a three-dimensional model co-segmentation method for sparse low-rank feature expression, comprising: pre-segmenting each three-dimensional model in the three-dimensional model category to obtain three-dimensional model facets of each three-dimensional model; three-dimensional model of each three-dimensional model The histograms of each 3D model are constructed separately to obtain the eigenvectors of each 3D model; the eigenvectors of each 3D model are processed with sparse low-rank expression to obtain the expression coefficient and expression error of each 3D model; The expression coefficient and expression error of each three-dimensional model are used to determine the trust expression coefficient of each three-dimensional model; the trust expression coefficients of each three-dimensional model are clustered, so as to co-segment each three-dimensional model respectively. The global consistency of similar 3D models is maintained, and the individual characteristics of a single 3D model are maintained; multiple expression results are correctly combined, and the correct rate of 3D model co-segmentation results is high.


Owner:BEIHANG UNIV
Dense reconstruction method of UAV scene based on vi-slam and depth estimation network
ActiveCN112435325BImprove generalization abilityGuaranteed accuracyImage analysisInternal combustion piston enginesPoint cloudReconstruction method
The present invention relates to a dense reconstruction method of unmanned aerial vehicle scenes based on VI-SLAM and depth estimation. External parameters and IMU external parameters are calibrated; (2) use the UAV monocular camera and IMU to collect the image sequence and IMU information of the UAV scene; (3) use VI‑SLAM to process the images and Process the IMU information to obtain the camera pose with scale information; (4) Input the monocular image information as the original view into the viewpoint generation network to obtain the right view, and then input the original view and the right view into the depth estimation network to obtain the depth of the image (5) Combine the camera pose obtained in step (3) with the depth map in step (4) to obtain a local point cloud; (6) After point cloud optimization and registration, combine the SLAM tracking trajectory with the local point cloud Cloud fusion to obtain a dense point cloud model of the UAV scene.


Owner:BEIHANG UNIV
A cross-data center fast query method and system based on mpp engine
ActiveCN107066546BGuaranteed global consistencyReliable transmissionMulti-dimensional databasesSpecial data processing applicationsConjunctive queryData retrieval
The invention relates to an MPP engine-based cross-data center rapid query method and system, belongs to the field of big data retrieval and analysis, and can be applied to real-time systems or offline backup systems. The method comprises the following steps of: uniformly marking data in different MPP engines and storing the data into metadata; receiving a query request by a global center point and carrying out grammar analysis on the query request, and sending the query request to corresponding data branch center nodes; carrying out query by each data branch center node through corresponding MPP engines of the metadata, and transmitting the data to the global center node; and rapidly querying the data returned by the data branch center points by the global center point by utilizing the MPP engines, and outputting a query result. According to the method and system, the union query of data of different data centers can be realized, a plurality of MPP engines are compatible, characteristics of different storage modes are sufficiently utilized to optimize the query, and the export of query result in a plurality of manners is supported, and convenience is brought to realize the different requirements, for result data re-analysis, of different upper applications.


Owner:NAT COMP NETWORK & INFORMATION SECURITY MANAGEMENT CENT
Rapid phase unwrapping method based on minimum balance tree
ActiveCN110824474AImprove computing efficiencyGuaranteed global consistencyRadio wave reradiation/reflectionForward propagationParallel processing
The invention discloses a rapid phase unwrapping method based on the minimum balance tree. A parallel processing mode is adopted, data quality parameters are obtained by winding difference values in ahorizontal direction and a vertical direction, positive and negative reliability maps are obtained through positive and negative residual point sources based on the forward propagation of a data quality map, the shortest phase discontinuity boundary is searched in combination with the propagation distribution of different residual point sources of opposite signs, and the reliability quality indexdistribution of the phase data angular points is iteratively constructed; and then reliability index based on the angular points is converted into an index of data points, non-incremental back propagation is performed on the basis of the index, a reliability index map of the absolute phase reckoning path is constructed, phase unfolding calculation is carried out by stages on the basis of calculating the reliability index map, global optimal unwrapping processing can be achieved, and meanwhile all solutions are based on a parallel mode.


Owner:NANJING UNIV OF POSTS & TELECOMM
Factor graph indoor positioning method based on fusion of multiple sensors
PendingCN114674314AGuaranteed global consistencyGuaranteed uptimeNavigational calculation instrumentsNavigation by speed/acceleration measurementsAlgorithmSimulation
The invention discloses a factor graph indoor positioning method based on fusion of multiple sensors, and the method comprises the steps: formulating a sensor factor according to a measurement model of the multiple sensors, inputting the sensor factor to a preset factor dynamic adaptation function as a factor node, and taking a robot navigation state as a variable node to construct a factor graph frame; performing nonlinear fusion on the obtained measurement data of the multiple sensors to obtain optimal state increment estimation of the navigation state of the robot; and calculating full navigation solutions of the robot in all navigation states in combination with an incremental smoothing algorithm. Measurement information of multiple sensors can be effectively fused, and the real-time performance and the positioning precision are improved.


Owner:TIANJIN CHENGJIAN UNIV
Vehicle pose processing method and device, electronic equipment and automatic driving vehicle
PendingCN114170297AGuaranteed global consistencyEasy to understandImage enhancementImage analysisIn vehicleEngineering
The invention provides a vehicle pose processing method and device, electronic equipment and an automatic driving vehicle, and relates to the field of artificial intelligence, in particular to the field of automatic driving. According to the specific implementation scheme, initial pose information of a vehicle at different moments is constructed, the initial pose information comprises an initial position and an initial pose, and the initial position is represented by longitude, latitude and elevation; real-time poses of the vehicle at different moments are collected, and the real-time poses are obtained through sensing of a plurality of sensors on the vehicle; and optimizing the initial pose information based on the real-time poses collected at different moments to obtain target pose information. In the process of optimizing the initial pose information by constructing the initial pose information and utilizing a plurality of sensors on the vehicle to sense and obtain the real-time pose, the used coordinates are longitude and latitude, switching of coordinate systems does not need to be considered, the global consistency is effectively ensured, and the accuracy of the optimization of the initial pose information is improved. The problem that in the prior art, in vehicle pose optimization, the coordinate origin needs to be replaced, and resetting is conducted continuously is solved.


Owner:APOLLO INTELLIGENT DRIVING (BEIJING) TECHNOLOGY CO LTD
A remote sensing image semantic parsing method based on topology-frequency domain collaborative field perception network
The present application relates to a kind of based on topological-frequency domain collaborative field sensing network's remote sensing image semantic analysis method, belong to remote sensing image semantic analysis technical field.The method includes: remote sensing image is initialized pretreatment, and image field representation is obtained;Topological-frequency domain collaborative field sensing encoder is constructed, and image field representation is carried out multi-level field decomposition and reorganization, and deep field representation is obtained;Field dynamic aggregation bottleneck layer is constructed, and deep field representation is carried out global field perception and sparse screening, and global optimization field feature is obtained;Field cognitive decoder is constructed, and global optimization field feature is inverted into pixel-level semantic field;Field cognitive loss function is constructed, and pixel-level semantic field is combined by back propagation training topological-frequency domain collaborative field sensing network, and the semantic field graph is output using trained topological-frequency domain collaborative field sensing network.It aims at solving the technical problems that existing technology has single cognitive dimension, feature fusion mean value, structure integrity loss and weak generalization ability.

Owner:KUNMING UNIV OF SCI & TECH