
Patents
Literature
33results about How to "Follow implementation" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
UWB-based autonomous following robot positioning method and system
InactiveCN105828431AFollow implementationFollow validPosition fixationWireless commuication servicesCarrier signalMobile robot
The invention relates to a UWB-based autonomous following robot positioning method and system. A specific target is a freely-moving person or object; at least three UWB base stations of which the positions are in a triangular form are fixed on a mobile robot; a UWB positioning label is arranged on the freely-moving person or object; the base stations send UWB signals; the label receives the UWB signals sent from the base stations; the label is time synchronization with the base stations, a TOA algorithm is utilized to obtain the distance between the label and the base stations, and then, geometric operation is utilized to obtain the coordinates of the label, and the position and movement information of the freely-moving person or object relative to the mobile robot can be determined, and the mobile robot can follow the person or object. According to the method and system of the invention, the UWB wireless positioning technology is utilized to realize autonomous following robot positioning, and narrow-band pulses are adopted to realize communication with carrier waves not required; and therefore, the method and system have the advantages of high transmission power, small power consumption, strong anti-interference ability and penetration ability as well as improved positioning precision and accuracy. With the method and system adopted, the following of the specific target can be realized.


Owner:UNIV OF SHANGHAI FOR SCI & TECH
Multi-axle steering track follow closed-loop control method for rubber wheel low-floor intelligent rail train
ActiveCN105292256AFollow implementationSimple control principleSteering for vehicles in tandemTurn angleEngineering
The invention discloses a multi-axle steering track follow closed-loop control method for a rubber wheel low-floor intelligent rail train. The multi-axle steering track follow closed-loop control method comprises the steps that firstly, according to a first wheel turn angle delta 1, input by a driver, of a first axle, the rotating angle of a second axle is controlled, and the track of the second axle is superposed with that of the first axle; secondly, the track of a third axle is made to be on the same circular arc with the traction of the second axle and the tract of the first axle to ensure superposition of the tracks by controlling an included angle phi of hinged points, wherein the hinged points are formed between two sections of carriages. The multi-axle steering track follow closed-loop control method has the advantages of being good in control effect, high in stability and the like.


Owner:CSR ZHUZHOU ELECTRIC LOCOMOTIVE RES INST
Radiological image equipment and automatic following method thereof
The invention discloses an automatic following method of radiological image equipment. The method comprises the steps of: obtaining a detector angle value; determining a handpiece target angle value corresponding to the detector angle value, wherein the target angle value is equal to the sum of the detector angle value and a preset value; and controlling a handpiece to carry out following motion to achieve the target angle. A synchronous following motion of the handpiece or a detector is realized when the angle of the detector or the handpiece in the radiological image equipment changes, the included angle of the X ray direction and the front surface of the detector is unchanged, and the method guarantees that the radiological image equipment is flexible in application and good in shooting effect.
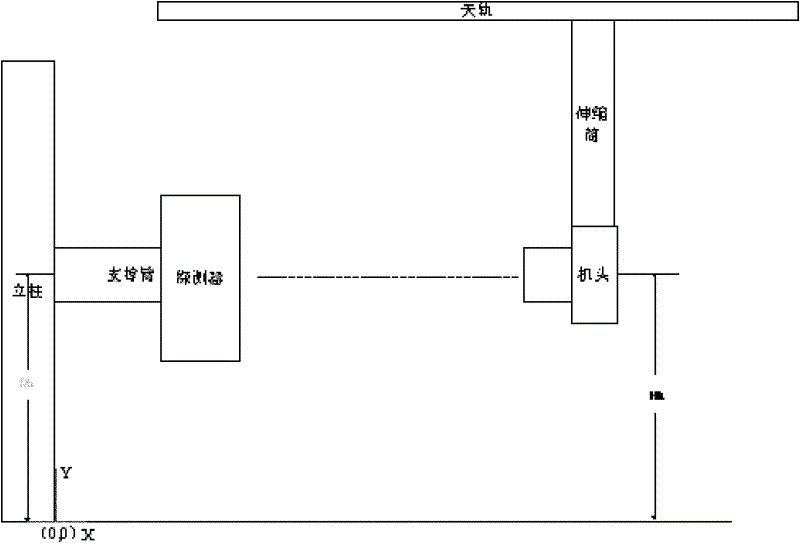
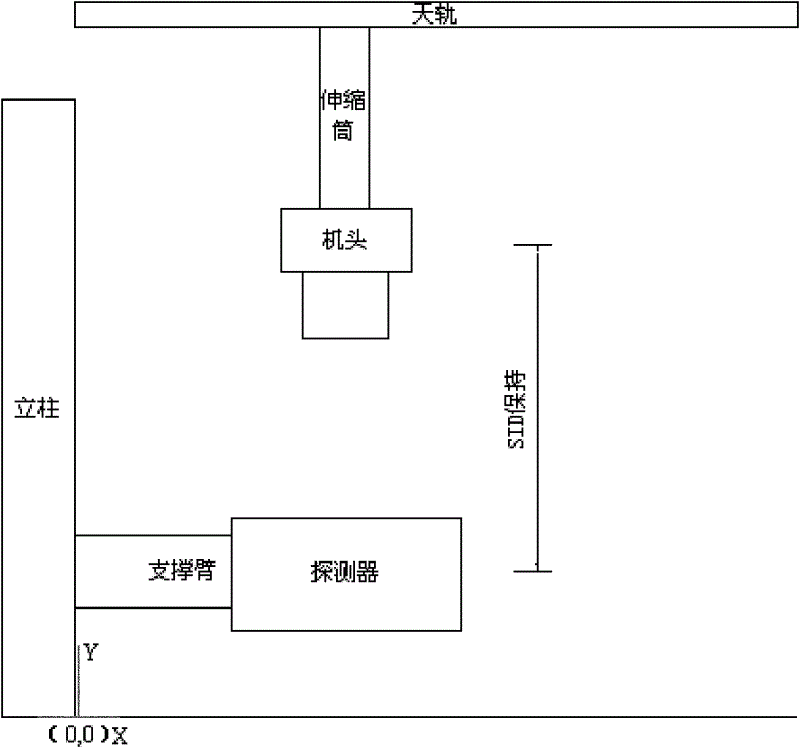
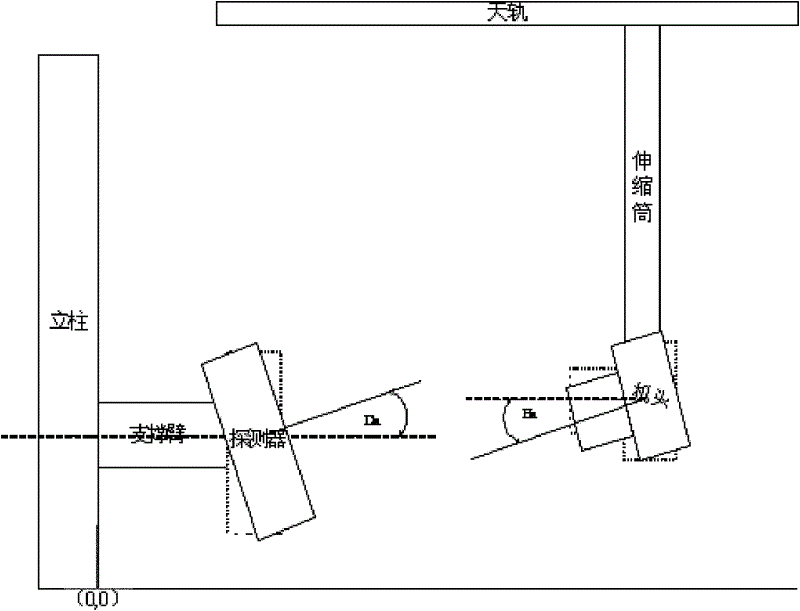
Owner:SHENZHEN MINDRAY BIO MEDICAL ELECTRONICS CO LTD
Target object following method of mobile robot based on monocular vision sensor
ActiveCN109166136AFollow implementationFollow validImage enhancementImage analysisObject tracking algorithmVision sensor
The invention relates to the field of computer vision identification, in particular to a target object following method of a mobile robot based on a monocular vision sensor, aiming at solving the problem that the robustness of the existing mobile robot following the target object is poor and the following quality of the target object such as a pedestrian is difficult to be guaranteed. For this purpose, the method provided by the present invention includes acquiring an image of a target object by a mobile robot according to a target area of the target object; obtaining a feature matrix of the image of the target object; using the target tracking algorithm and the feature matrix to determine the center point of the target object; determining a region in which the target object is located according to the center point and the outline frame of the target object. As a first region, whether the proportion of the area of the first region in the image of the target object is larger than a setthreshold value is judged, and performing corresponding operations according to the judgement result. Based on the above steps, the method provided by the invention has real-time performance and goodrobustness, and can effectively follow the target object.


Owner:INST OF AUTOMATION CHINESE ACAD OF SCI
Full-automatic intelligent following luggage car
InactiveCN106965835AFollow implementationAvoid cumbersomeSledge wheelsPosition/course control in two dimensionsDrive wheelCentral processing unit
The invention discloses a full-automatic intelligent following luggage car capable of achieving following operation according to a given trajectory. The full-automatic intelligent following luggage car comprises a luggage car body and a following system. The luggage car body comprises a main car body and a roller device arranged on the lower portion of the main car body and distributed in a triangle mode. The roller device is composed of a drive wheel arranged on the front of the lower portion of the main car body, and driven wheels symmetrically arranged on the two sides of the rear side of the lower portion of the main car body. A drive mechanism is arranged inside the main car body. The following system comprises a signal emitting device and a signal receiving device. The signal receiving device is sequentially connected with a central processor and a logic arithmetic unit. The logic arithmetic unit is connected with the drive mechanism and a steering mechanism. By adopting the following system to control movement of the main car body, following of the luggage car and a user is achieved on the premise that the user does not perform any operation on the luggage car, and troubles and labor waste caused by purely manual pushing of the car are avoided.


Owner:SICHUAN COLLEGE OF ARCHITECTURAL TECH
Active thread and contour scanning device and method
PendingCN107976156AFollow implementationAccurately reflectUsing optical meansEngineeringMovement system
The invention provides an active thread and contour scanning device, and the device comprises a measuring probe, a force measurement feedback mechanism, a horizontal measuring rod, a horizontal pull detection mechanism, and a movement system. The measuring probe is disposed on the force measurement feedback mechanism, and the force measurement feedback mechanism is connected with the horizontal pull detection mechanism through the measuring rod. The horizontal pull detection mechanism is connected with the movement system. The invention also provides an active thread and contour scanning method based on the device. The beneficial effects of the invention are that the device and method guarantee that a measured force in a measurement process is basically constant through the real-time adjustment of the amplitude of the measured force, thereby guaranteeing that the measured data reflects the thread and contour surface more really; the device and method solve problems of climbing and descending in a scanning process, such as a problem that the measuring probe breaks away from the surface of a workpiece, and a problem that the measuring probe is clamped and damaged; the device and method increase the scanning speed.


Owner:CHOTEST TECH INC
Character motion following method and device, computing device and storage medium
ActiveCN110292773ARealize intelligent follow-upFollow implementationVideo gamesComputer visionAlgorithm
The invention provides a character motion following method and device, a computing device and a storage medium. The character motion following method includes the steps that according to set recordingfrequency, a position point of a main character and corresponding state information of the position point are recorded; when it is determined that the distance between the main character and a non-player character NPC is greater than a distance threshold, the position point of the main character within the first distance range from the current position of the NPC is found, the NPC is endowed withstate information corresponding to the position point to enable the NPC to follow movement of the main character according to the state information corresponding to the position point, thus intelligent following of the NPC to a game character is realized, and the game experience is improved.


Owner:ZHUHAI SEASUN MOBILE GAME TECH CO LTD
UWB-based device following method, device and system
The invention discloses a UWB-based device following method, device and system, and relates to the technical field of computers. One embodiment of the method comprises the steps of: obtaining an identifier of a UWB following unit, combining identification association record of a predetermined UWB following unit and a UWB wearing unit, and determining the UWB wearing unit associated with the UWB following unit; according to the identifiers of the UWB following unit and the UWB wearing unit, obtaining current coordinate values of the UWB following unit and the UWB wearing unit to determine a distance of the UWB following unit and the UWB wearing unit; and if the distance exceeds a predetermined distance threshold value, transmitting an acceleration command to a rolling unit associated with the UWB following unit to drive the roller of the rolling unit for accelerated rolling. According to the embodiment mode, a following device is bound on a luggage box to achieve automatic following ofthe luggage in a public place so as to effectively avoid the condition of collision and disengagement of the luggage.


Owner:JD DIGITS HAIYI INFORMATION TECHNOLOGY CO LTD
Robot and target following obstacle avoidance method based on the same, system, equipment and medium
PendingCN109062215AFollow implementationPosition/course control in two dimensionsObstacle avoidanceEngineering
The invention discloses a robot and a target following obstacle avoidance method based on the same, a system, equipment and a medium. The target following obstacle avoidance method comprise the following steps: controlling the robot to acquire a target location of a followed target; determining whether obstacles are existent in the preset horizontal width range at two sides of a first connecting line of the current location and a target location of the robot, wherein the preset horizontal width is not less than a rotation semi-diameter of the robot; if the preset horizontal width is not less than the rotation semi-diameter of the robot, determining a transfer location, and the obstacles are inexistent in the preset horizontal width range at two sides of a second connecting line of the current location and the transfer location of the robot; controlling the robot to move to the transfer location, and continuously executing the step of controlling the robot to acquire the target locationof the followed target; if the preset horizontal width is less than the rotation semi-diameter, controlling the robot to move to the target location. The robot disclosed by the invention avoids the obstacle by moving to the transfer location when the obstacle is existent and moves to the target location until the obstacle is inexistent on the straight distance of the current location of the robotand the followed target, thereby following the target.
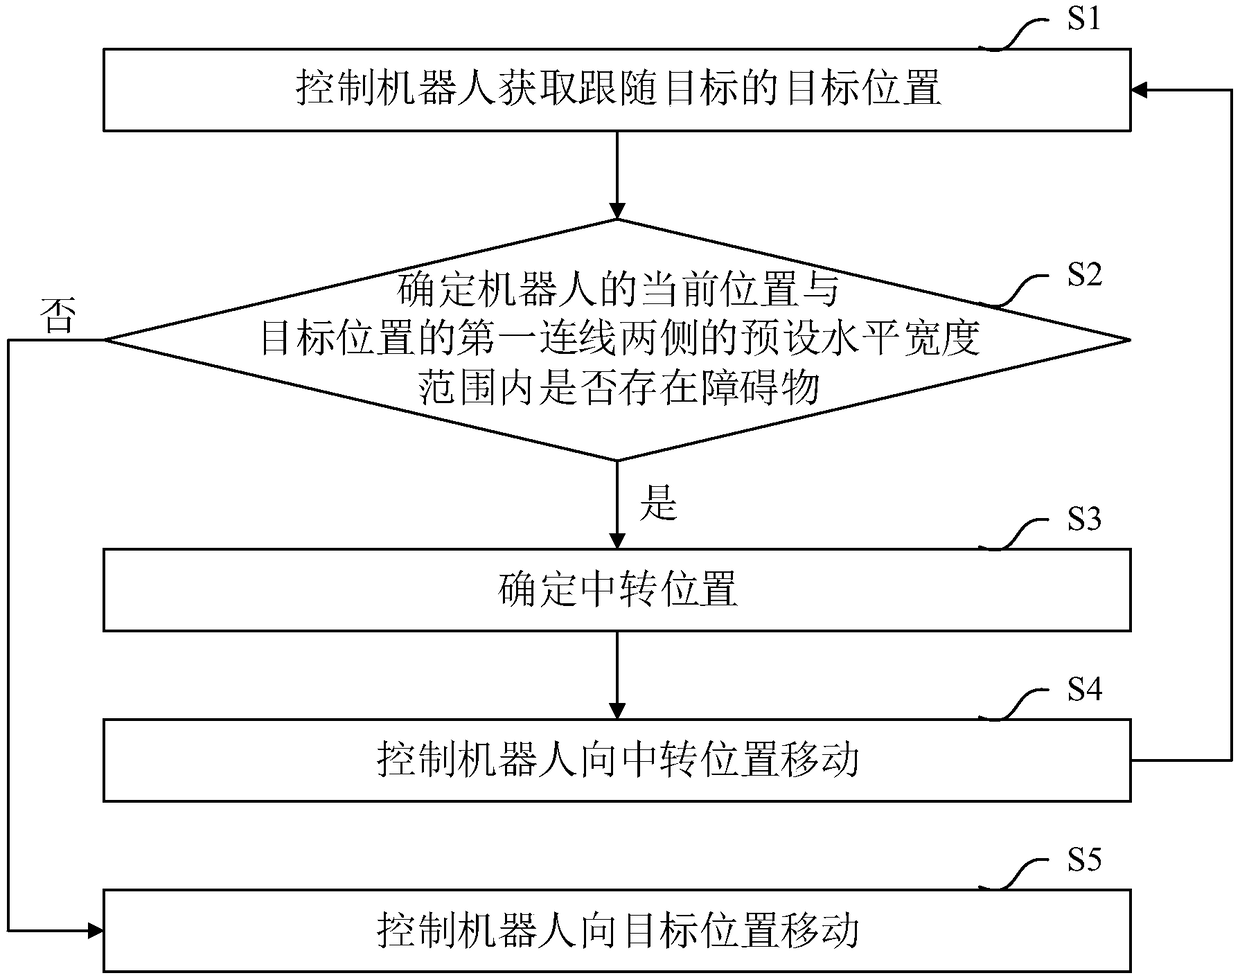
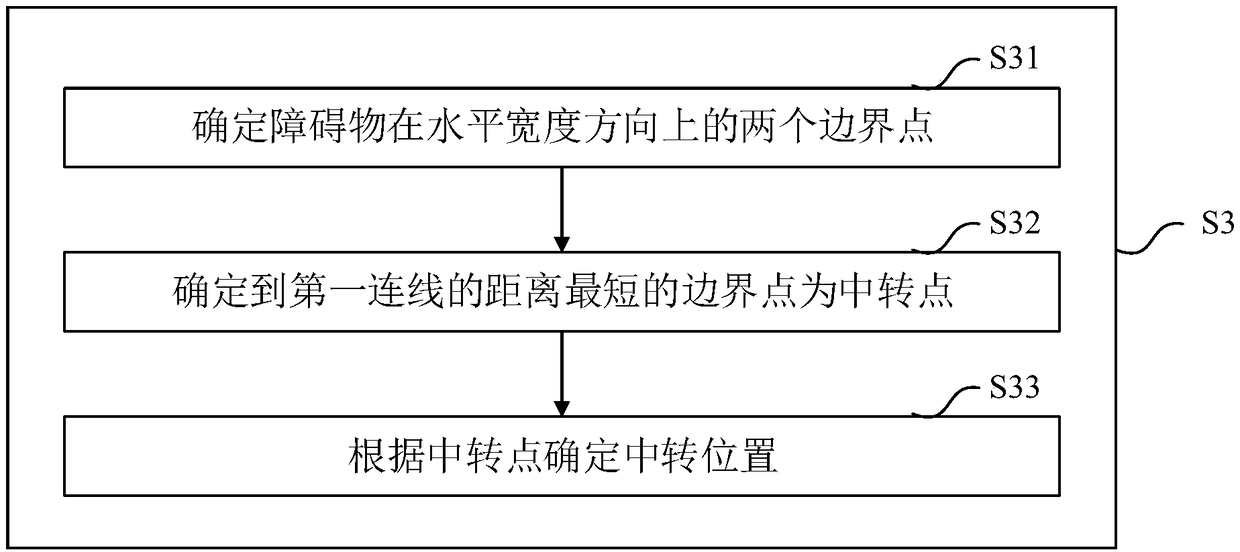
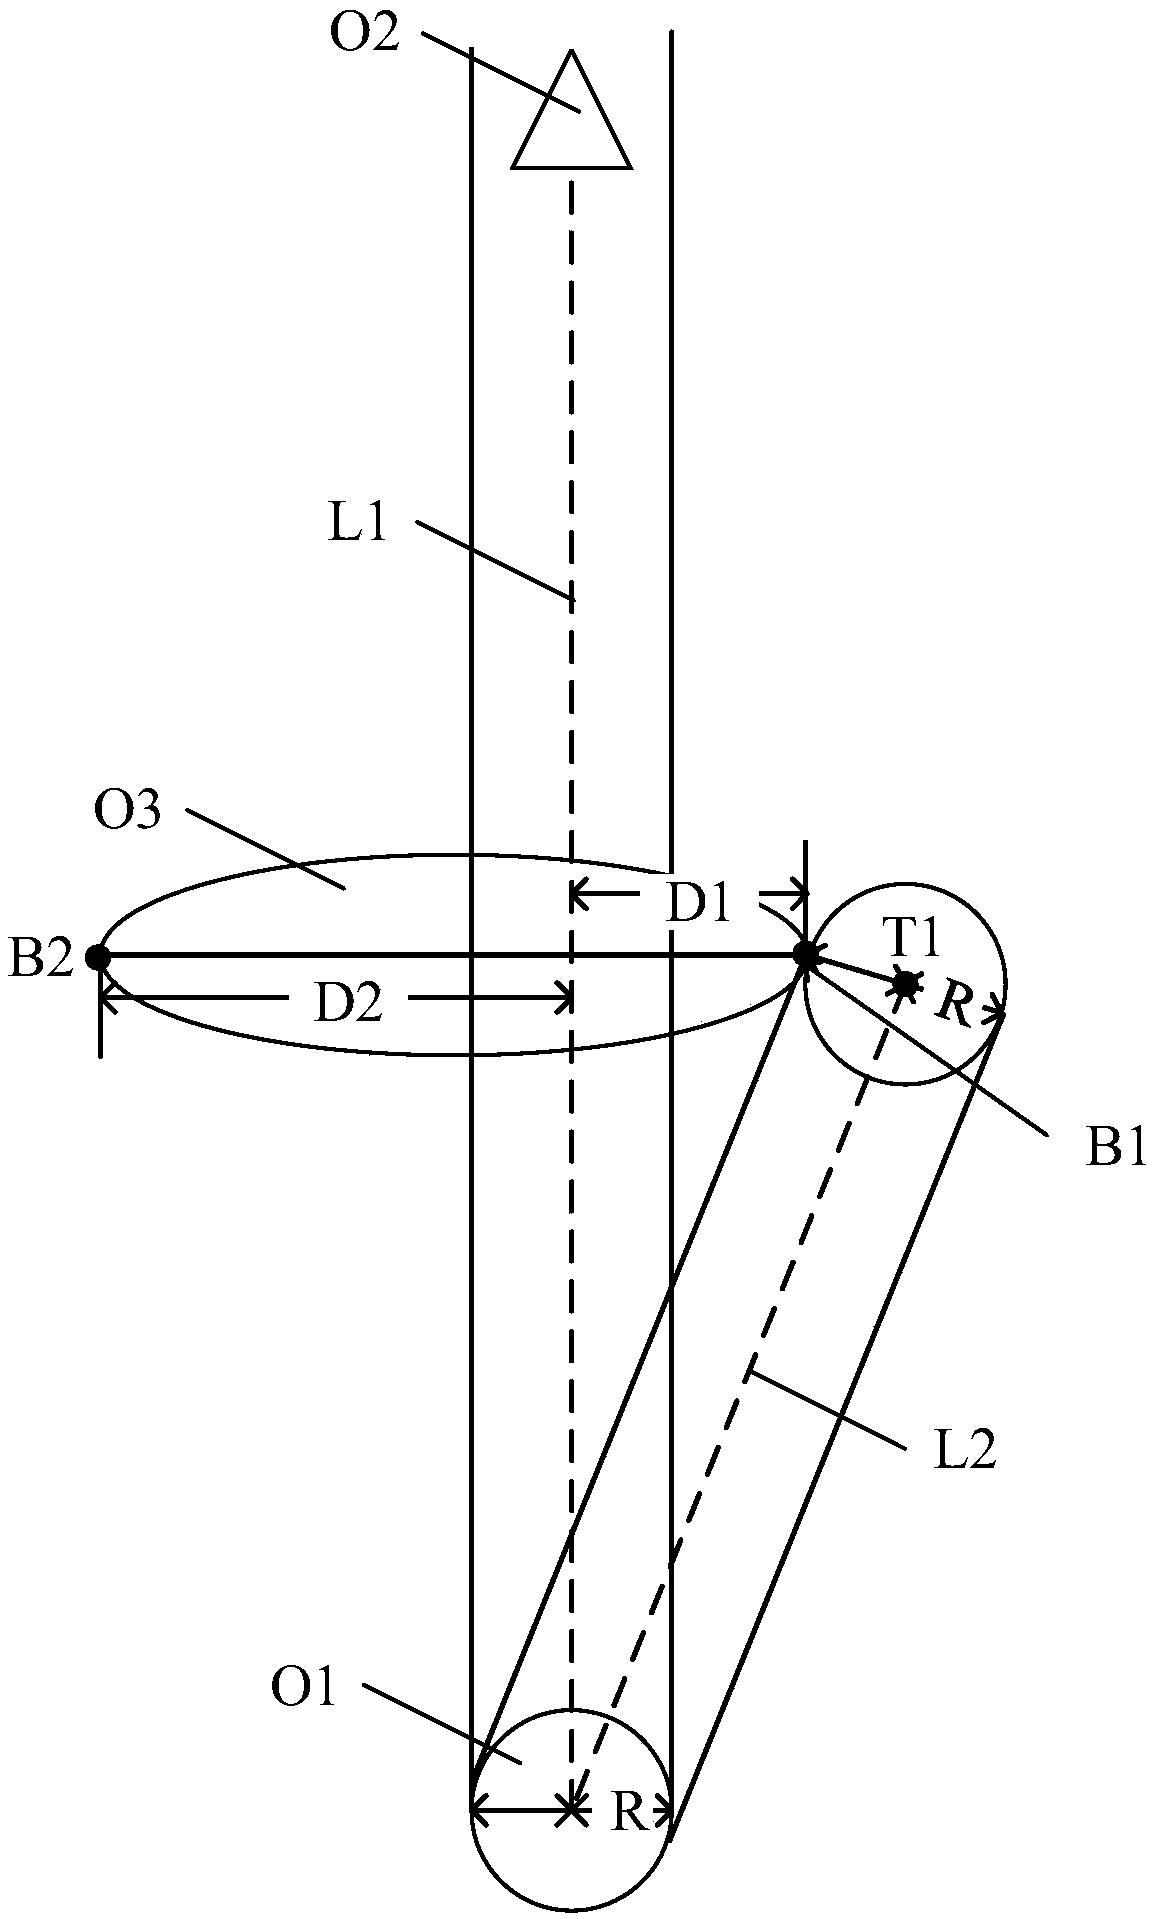
Owner:BEIJING JINGDONG SHANGKE INFORMATION TECH CO LTD +1
Robot following system and robot following method
InactiveCN110032213AFollow implementationEasy to distinguishTarget-seeking controlSimulationControl theory
The invention relates to a robot following system and a robot following method. A target follower selects a first initial position, obtains first position information and second position information,and obtains position movement information according to the first position information and the second position information, so that an initialization module controls a robot body to perform posture initialization according to the first position information; a driving module drives the robot body to perform corresponding trajectory movement according to the position movement information; and thus, following of the robot body on the target follower is realized. In a process of following the target follower by the robot body, the robot body is controlled by the target follower; a specific target can be determined without positioning the target follower by the robot body; an obstacle is convenient to distinguish; and the target is not distributed by other objects.


Owner:SHEN ZHEN TALUER TECH CO LTD
UWB-based following system and article transfer cart
InactiveCN113126600AFollow implementationEasy to movePosition/course control in two dimensionsVehiclesInformation controlControl engineering
The invention discloses a UWB-based following system and an article transfer cart. The system comprises a UWB sensor, a controller and a driving module, wherein theUWB sensor is used for obtaining the first position information of a followed object and the second position information of the UWB sensor in real time; the controller is connected with the UWB sensor, and is used for receiving the first position information and the second position information, acquiring the distance and the direction angle between the controller and the followed object according to the first position information and the second position information, and generating a moving instruction according to the distance and the direction angle; and the driving module is connected with the controller and is used for receiving the moving instruction and driving the moving object to move according to the moving instruction. The position information of the followed object is locked through the UWB sensor, the followed object is followed to move according to the position information, and the followed object can be followed to move without other auxiliary guide devices.


Owner:SHENYANG SIASUN ROBOT & AUTOMATION
Balance car control method and device
ActiveCN106347550BImprove reliabilityImprove securityMotorised scootersBicyclesComputer moduleComputer science
The invention relates to a method and device for controlling a balance car. The method for controlling the balance car includes the steps that a target two-dimensional code is scanned through a camera; the target two-dimensional code is arranged on a target; the position of the two-dimensional code is determined according to scanning information of the camera; control information for controlling the driving direction and driving speed of the balance car is generated according to the position of the target two-dimensional code to enable the balance car to follow the target. Thus, the purposes that when the balance car is not used, the balance car can automatically follow the target to move towards the target without being lifted or pushed by a user, and therefore automatic following of the balance car is achieved can be achieved; due to the adoption of the two-dimensional code, a processing program of a processor can be simplified, and the recognition reliability of the target is improved; azimuth information and distance information of the target two-dimensional code are determined according to the rotating angle of the camera and the focal length generated when the target two-dimensional code is scanned, no additional ranging module needs to be added, and cost can be reduced.


Owner:BEIJING XIAOMI MOBILE SOFTWARE CO LTD
High-linearity wide-swing CMOS voltage follower
PendingCN111384940AFollow exactlyFollow the exact implementationReliability increasing modificationsLogic circuits coupling/interface using field-effect transistorsCMOSTerminal voltage
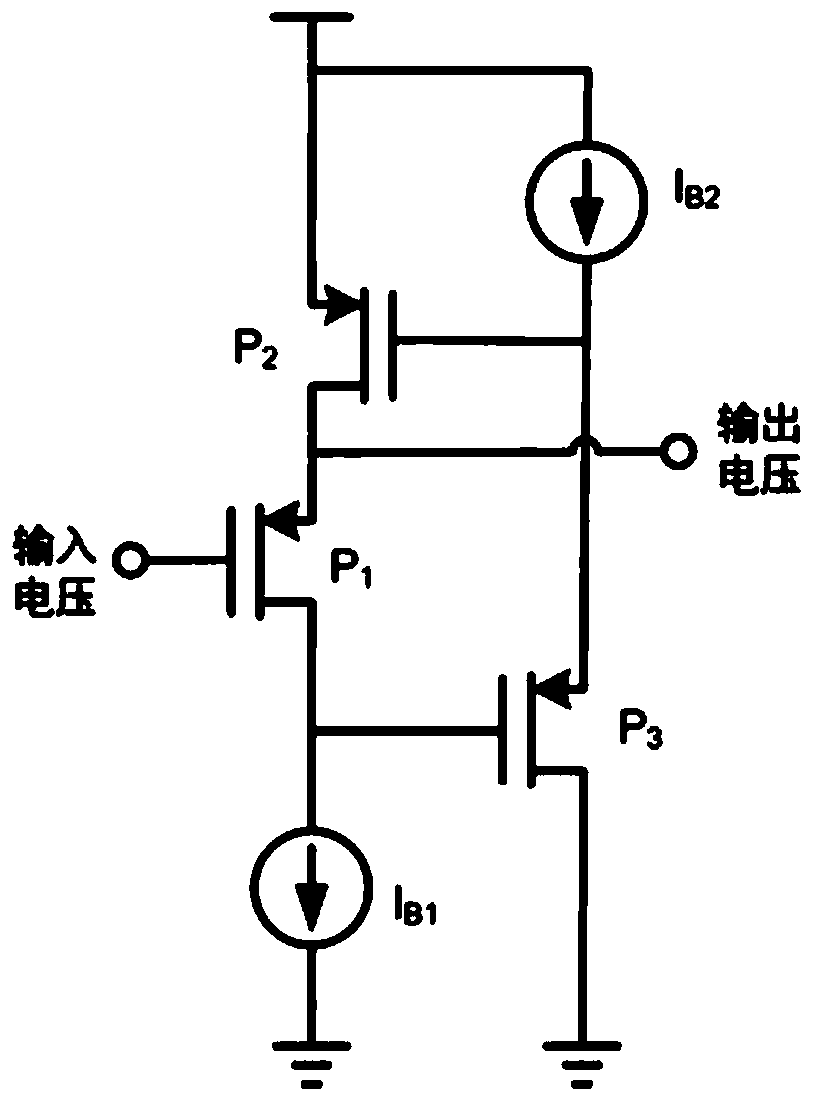
The invention discloses a high-linearity wide-swing CMOS voltage follower, which has the advantages that when an input voltage is as low as 0 V, all MOS tubes can fully work in a saturation region, sothat normal operation of the voltage follower can be ensured; along with the increase of the input voltage, a drain end voltage of the PMOS tube P9 is close to a power supply voltage VDD, and the PMOS tube P9 enters a linear region, so that a grid voltage of the PMOS tube P9 is sharply reduced, but the voltage follower can still operate normally as long as the grid voltage of the PMOS tube P9 does not drop to force the NMOS tube N3 to enter the linear region. Therefore, the grid voltage of the PMOS tube P9 can be as low as 2 Vdsat, and the swing of the grid voltage of the PMOS transistor P9 is allowed to be greatly expanded.
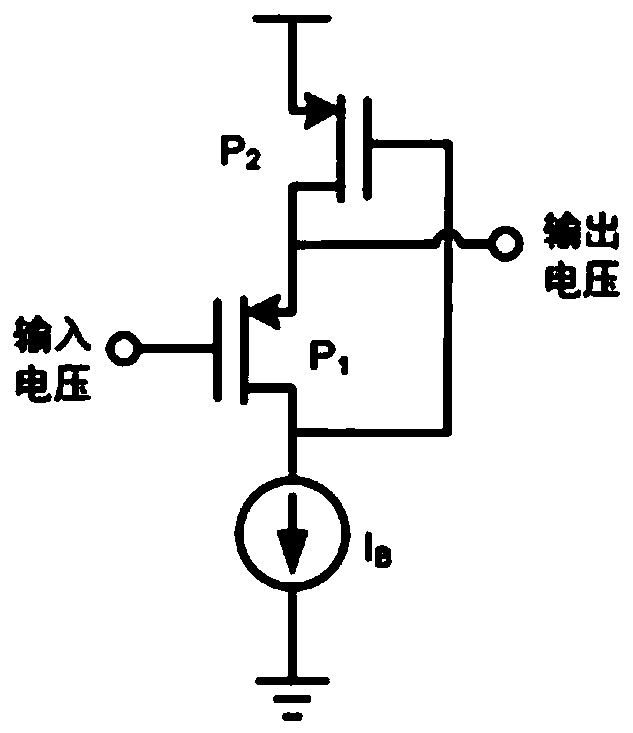
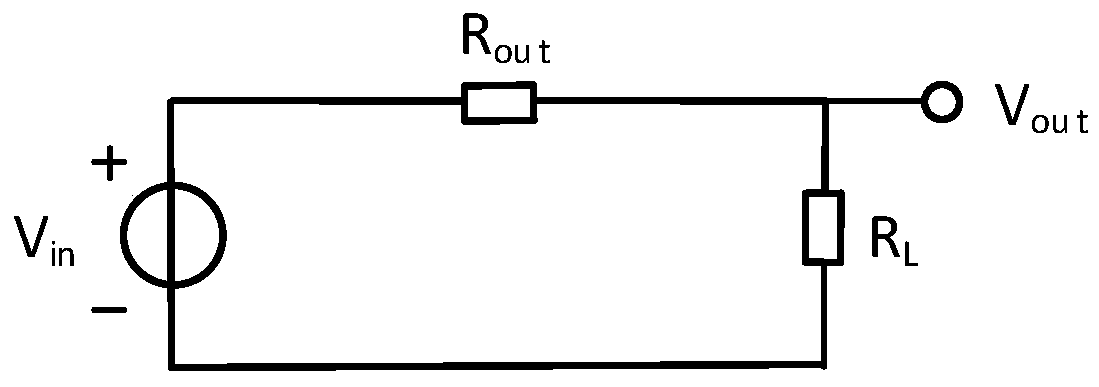
Owner:SUZHOU UNIV
Robots following person method, device and storage media, and robot
ActiveCN108717302AFollow the charactersRealize automatic followTarget-seeking controlEvaluation functionBody sensors
The present invention relates to the field of robots, and in particular to a robot following person method, device, and storage medium, and a robot, the method comprises the following steps of: detecting a target person through a body sensor installed on the robot, and acquiring the relative coordinates relative to the robot of the target person of in an original coordinate system; converting therelative coordinates to second world coordinates of the target person in a world coordinate system according to the first world coordinates of the robot in a world coordinate system; according to a random expansion tree algorithm and the evaluation function based on the A * algorithm, calculating and filtering the intermediate node of the random extension tree; when the distance between the intermediate node and the second world coordinates is within a preset range, sequentially connecting each intermediate node to form a target path, and controlling the robot to move from the first world coordinates along the target path to the second world coordinates in a world coordinate system.


Owner:PING AN TECH (SHENZHEN) CO LTD
Blade following control method and device and operation machine
PendingCN114397888ASimple structureHigh precisionPosition/course control in two dimensionsVehiclesDistance measurementControl engineering
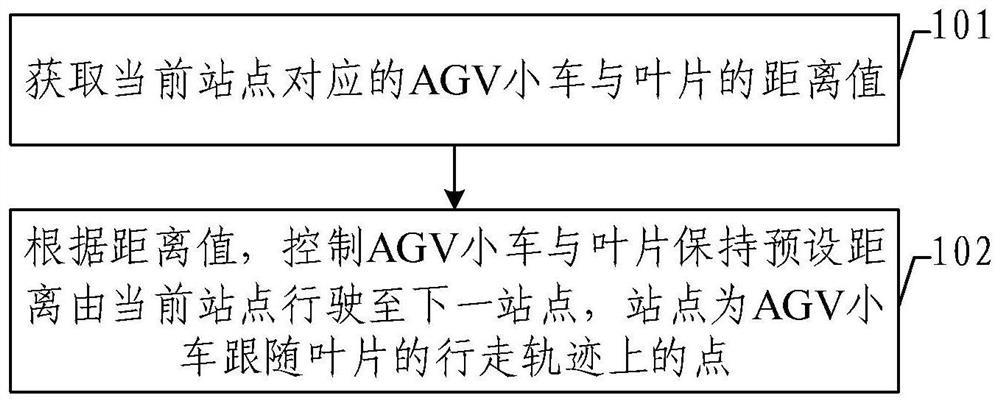
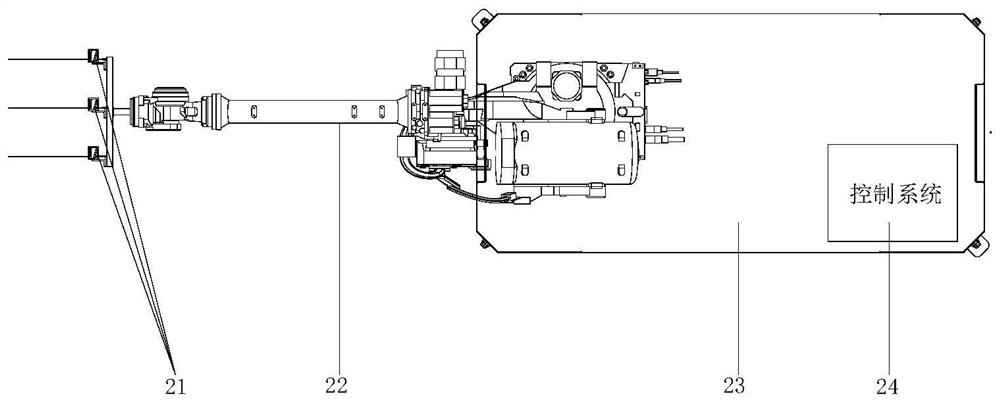
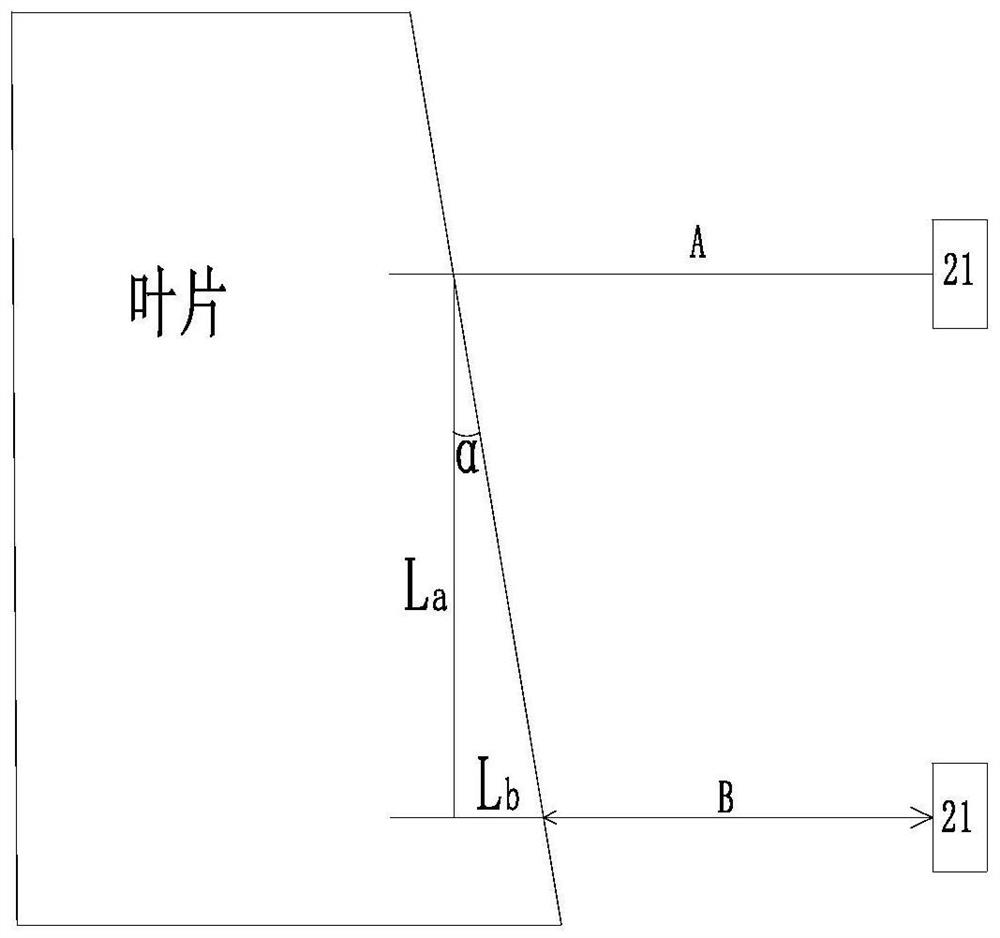
The invention provides a blade following control method and device and an operation machine.The method comprises the steps that the distance value between an AGV corresponding to a current station and a blade is obtained, according to the distance value, the AGV and the blade are controlled to keep a preset distance to run from the current station to the next station, and the station is a point on the walking track of the AGV following the blade; the blade can be followed only by obtaining the distance value between the AGV trolley and the blade, the influence of the blade on distance measurement can be avoided while the structure of the blade is simplified, the blade following accuracy of the AGV trolley is effectively improved, the relative position of the blade and the AGV trolley is guaranteed, and operation of related equipment on the blade is more convenient.
Owner:三一机器人科技有限公司
Escalator safety device with induction recognition function
InactiveCN112125115AFollow implementationEnsure safetyMechanical energy handlingEscalatorsEngineeringAir cavity
The invention discloses an escalator safety device with an induction recognition function. The escalator safety device with the induction recognition function comprises arrangement plates. A transmission mechanism is arranged on each arrangement plate and comprises a first air cylinder, wherein the first air cylinder is fixed to the upper end surface of the arrangement plate, a first air cavity isformed in the first air cylinder, and a first piston is arranged in the first air cavity in a sliding mode. An induction box is fixedly arranged on the upper end surface of each arrangement plate andlocated at the side, away from an escalator handrail, of the corresponding first air cylinder. By means of the escalator safety device, whether objects on steps of an escalator are suspended or not can be inducted and recognized, and following movement of the whole mechanism is achieved by means of the characteristic that the handrails synchronously move along with the escalator; and torsional springs, rotating plates and clamping rods are used for assisting in fixing the suspended objects, so that the suspended objects do not roll down, and the safety of people on the escalator is guaranteed.


Owner:深圳市鸿跃新科技有限公司
A rs232 communication interface circuit supporting hot plugging
ActiveCN109144929BWide level shifting rangeEnhanced level matching capabilityElectric digital data processingLevel shiftingHemt circuits
The invention discloses a RS232 communication interface circuit that supports hot swapping. The interface circuit uses a high-speed operational amplifier as a core device, and is equipped with corresponding peripheral devices to form a voltage buffer; a three-stage tube is used as an inverter, and the phase is reversed twice consecutively. , obtain the same phase transmission level, and also realize the wide voltage range of the interface circuit, meet the requirements of the RS232 communication frequency band, realize the hot swap of the serial port circuit, and meet the voltage requirements between different devices and different signal levels. The power supply circuit of the interface circuit can follow the input voltage, and can overcome the surge voltage and surge current during the hot swapping process. The invention has high integration degree, small volume, simple circuit connection mode and low failure rate. In the case of failure, it can also facilitate fault detection and analysis, and troubleshoot and repair. The invention can be used in the transmission of different signal levels of each RS232, and has level conversion, signal buffering, hot plug function and high reliability.


Owner:NORTHWESTERN POLYTECHNICAL UNIV
Radiological image equipment and automatic following method thereof
The invention discloses an automatic following method of radiological image equipment. The method comprises the steps of: obtaining a detector angle value; determining a handpiece target angle value corresponding to the detector angle value, wherein the target angle value is equal to the sum of the detector angle value and a preset value; and controlling a handpiece to carry out following motion to achieve the target angle. A synchronous following motion of the handpiece or a detector is realized when the angle of the detector or the handpiece in the radiological image equipment changes, the included angle of the X ray direction and the front surface of the detector is unchanged, and the method guarantees that the radiological image equipment is flexible in application and good in shooting effect.


Owner:SHENZHEN MINDRAY BIO MEDICAL ELECTRONICS CO LTD
Vehicle automatic following system, method, device and computer readable medium
The invention provides an automatic vehicle following system, a method, a device and a computer readable medium, and the system comprises an image obtaining module which is used for obtaining an image of a surrounding area of a vehicle at a set frequency; an image processing and feature extraction module which is configured to process the image and obtain a following target object image and following target object image features; arranging the following target object image features according to priorities to form following target object image features with different priorities; and a following control module which is used for controlling the vehicle to follow the following target object based on the image features of the following target object with different priorities. According to the system, effective and timely following of the following target object by the vehicle can be realized.


Owner:HOZON NEW ENERGY AUTOMOBILE CO LTD
A robot following method, device and system
ActiveCN113858216BFollow implementationPrivacy protectionProgramme-controlled manipulatorSound sourcesUser privacy
The application discloses a robot following method, device and system. By separating and identifying the sound source of the sound signal in the environment, it is determined whether the sound signal matching the target pedestrian is included in the environment. The voice of the target pedestrian can be followed, and the position of the target pedestrian can be determined without obtaining the image of the target pedestrian through the camera, which protects the privacy of the user and improves the user experience.


Owner:NANKAI UNIV
Analog input following processing circuit for variable-frequency governor
InactiveCN103246218AFollow implementationAchieve freedom of choiceProgramme control in sequence/logic controllersVIT signalsVoltage
The invention discloses an analog input following processing circuit for a variable-frequency governor. The analog input following processing circuit comprises a photoelectric isolation circuit and a power supply circuit, and is characterized in that one end of the photoelectric isolation circuit is connected with a host computer through a voltage and current magnitude selection circuit, and the other end is connected an analog input terminal of the variable-frequency governor through a differential amplifying circuit; and the power supply circuit is connected with the photoelectric isolation circuit and the differential amplifying circuit respectively. The analog input following processing circuit is mainly used for processing an input analog given signal of the variable-frequency governor.


Owner:XIANGMEI LEADER MINING EQUIP
Electronic control device for multi-rotor aircraft, electronic control device for aerial photography of multi-rotor aircraft and follow-up aerial photography multi-rotor aircraft
ActiveCN104133484BSolve following problemFollow implementationTransmission systemsSatellite radio beaconingTransceiverGeolocation
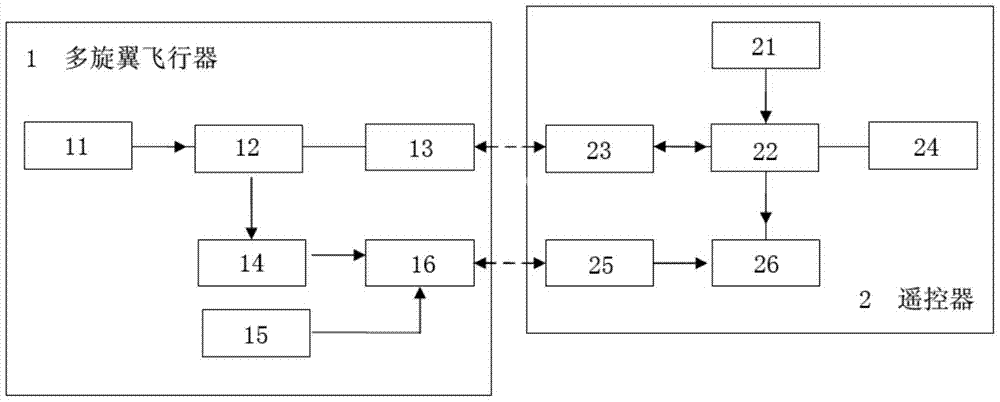
The invention discloses an aerial shooting electronic device of a multi-rotor aircraft. The aerial shooting electronic device comprises a first locating receiver used for instantly locating the geographical position of the multi-rotor aircraft, an aircraft control chip connected with the first locating receiver, a first transceiver antenna connected with the aircraft control chip, a motion camera used for aerial shooting, a second locating receiver used for instantly locating the geographical position of a remote controller, a main control chip connected with the second locating receiver, a second transceiver antenna connected with the main control chip, and a mode selection switch used for switching the aerial shooting state. An aircraft controller controls the first locating receiver to acquire the geographical position information of the aircraft controller, the geographical position information is sent through the first transceiver antenna to the second transceiver antenna to enable the main control chip to acquire and judge the position information and control the multi-rotor aircraft to fly toward the geographical position of the remote controller, and multiple times of aerial shooting are carried out in the flying process. The invention further discloses a multi-rotor aircraft electronic control device and an aerial shooting following multi-rotor aircraft.
Owner:ZHEJIANG FEISHEN VEHICLE IND CO LTD
Target recognition and follow method
ActiveCN109740464BFollow implementationCharacter and pattern recognitionFeature extractionEngineering
The present invention provides a method for identifying and following a target, comprising: acquiring video data around the vehicle; performing feature extraction on a single frame / or multi-frame image information to determine features to be matched; The facial features in the feature library are matched to determine the first matching degree; and / or, the suspicious item features are matched with the item features in the preset second feature library to determine the second matching degree and determine the suspicious object; The image information corresponding to the suspicious object determines the state and path of the suspicious object; when the state of the suspicious object is moving, a follow command is sent to the follow device on the vehicle so that the follow device follows the suspicious object; the follow command includes waiting Among the matching features, the successfully matched suspect face features and / or the successfully matched suspicious item features and paths. In this way, the follow-up of suspicious objects is realized without affecting the current work.

Owner:BEIJING ZHIXINGZHE TECH CO LTD
Robot following character method, device and storage medium, robot
ActiveCN108717302BRealize automatic followFollow implementationTarget-seeking controlEngineeringComputer vision
The present invention relates to the field of robots, in particular to a method and device for a robot to follow a person, a storage medium, and a robot. The method includes: detecting a target person through a somatosensory detector installed on the robot, and obtaining the location of the target person in the original coordinate system. Under the relative coordinates relative to the robot; according to the first world coordinates of the robot in the world coordinate system, the relative coordinates are converted into the second world coordinates of the target character in the world coordinate system; according to the random expansion tree algorithm and The evaluation function based on the A* algorithm calculates and screens the intermediate nodes of the randomly expanded tree; when the distance between the intermediate nodes and the second world coordinates is within a preset range, the intermediate nodes are sequentially connected to form a target path, and the control of the The robot moves from the first world coordinate to the second world coordinate along the target path in a world coordinate system.


Owner:PING AN TECH (SHENZHEN) CO LTD
Robot following method, robot and storage medium
ActiveCN107544506BTimely interactionImprove perceptionPosition/course control in two dimensionsSimulationComputer vision


Owner:SHANGHAI YOGO ROBOTICS CO LTD
Multi-robot grouping and tracking control method and system
PendingCN119575975Afollow implementationImprove team efficiencyVehicle position/course/altitude controlPosition/direction controlMachineHuman–robot interaction
The invention belongs to the technical field of robot formation, and provides a multi-robot team formation and tracking control method and system, and the method comprises the steps: analyzing a voice signal, taking a subject in the voice signal as the number of a navigator robot, and taking an object in the voice signal as the number of a follower robot, thereby completing the team formation; taking image acquisition of the follower robot as an original point, establishing a coordinate system, and converting the established coordinate system into a pixel coordinate system; determining a pixel value of a navigator robot on a pixel plane in the pixel coordinate system; the direction between the follower robot and the navigator robot is determined according to the pixel value, and the distance between the follower robot and the navigator robot is determined according to the voice signal transmission time; performing tracking control according to the determined direction and distance; the team forming information is transmitted in a voice processing sequence analysis mode, and the team forming efficiency is greatly improved compared with the mode that an operator performs robot identity assignment or team member team forming through a man-machine interaction screen in the modes of clicking, dragging and the like.

Owner:QILU UNIVERSITY OF TECHNOLOGY (SHANDONG ACADEMY OF SCIENCES)
Mobile robot following method and system
PendingCN113741550AFollow implementationAutomatically avoid static obstaclesAutonomous decision making processTarget-seeking controlEngineeringGlobal optimal
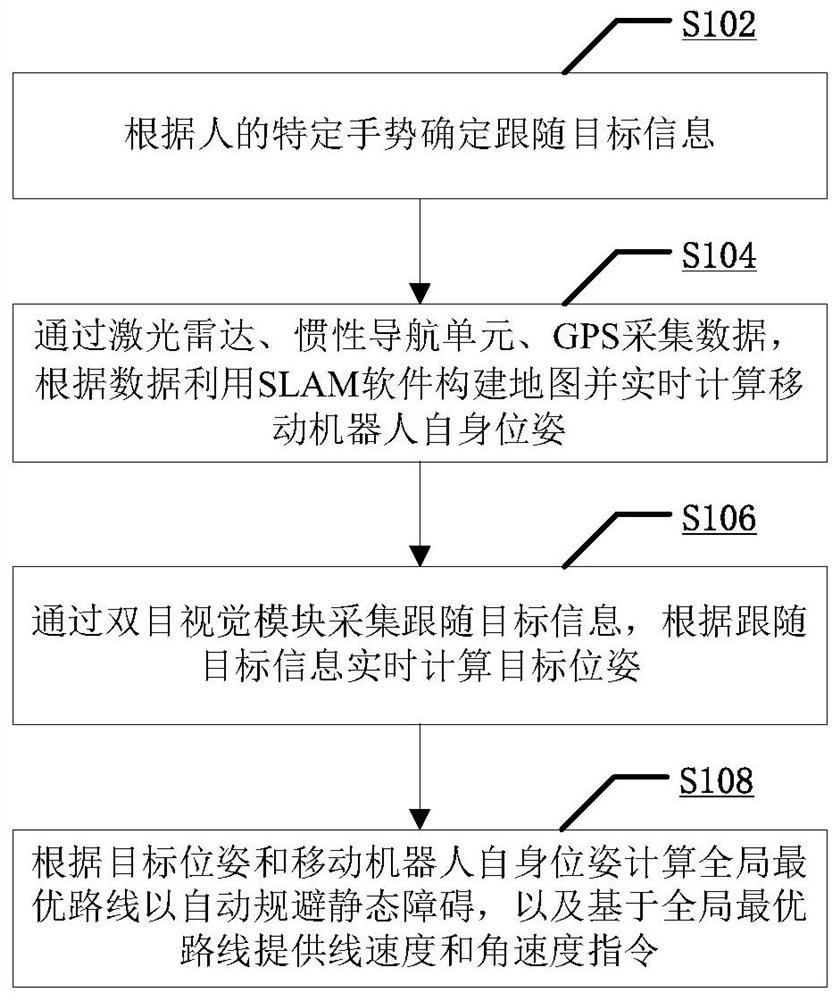
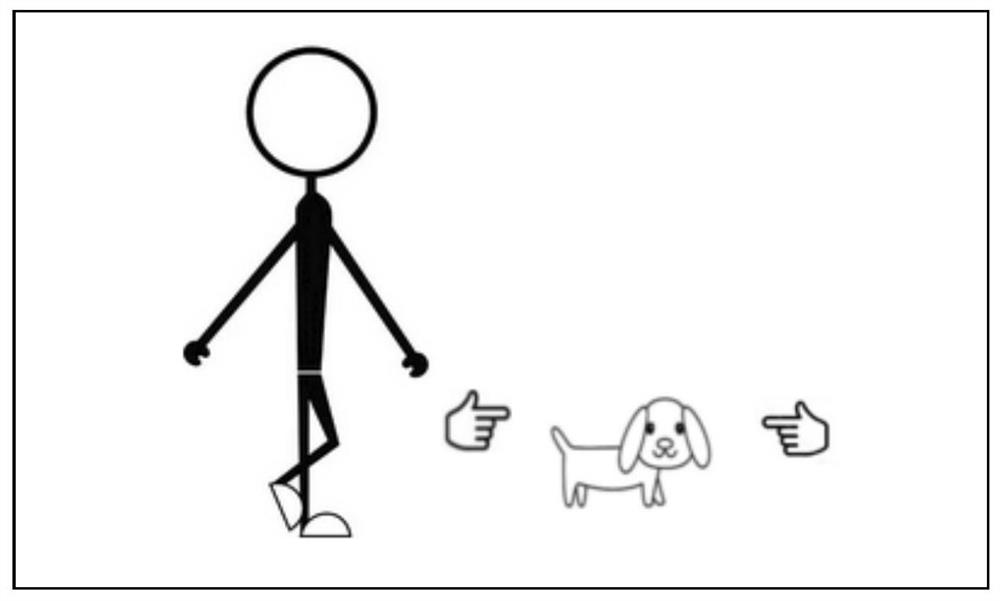
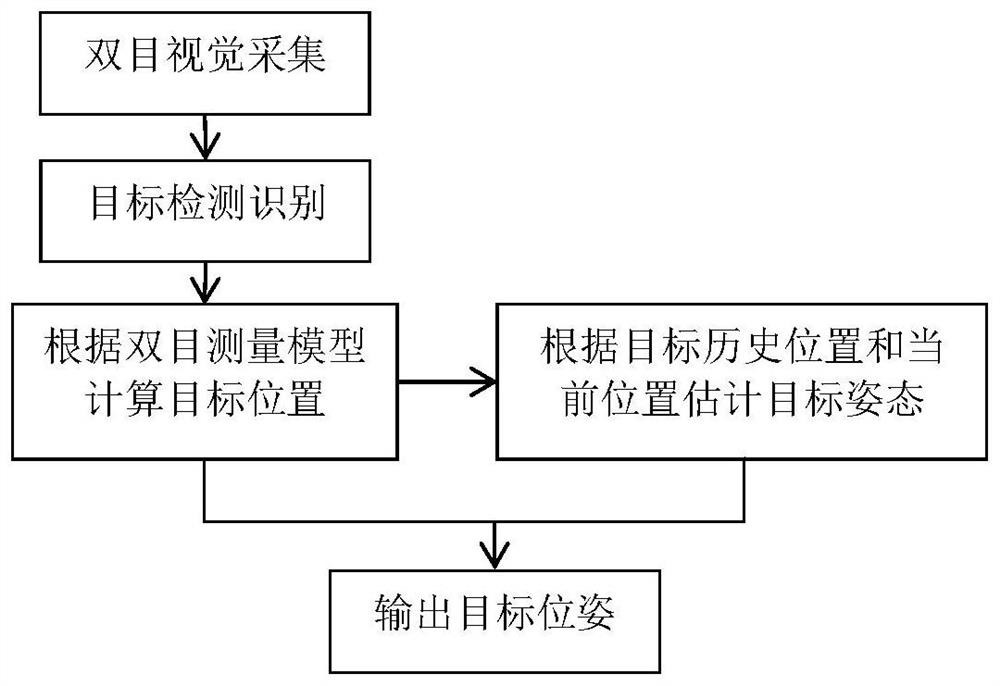
The invention relates to a mobile robot following method, belongs to the technical field of artificial intelligence, and aims to solve the problems of non-cooperative target following, tedious following target determination and the like of an existing following method. The following method comprises the steps of: determining following target information according to a specific gesture of a person; collecting data through a laser radar, an inertial navigation unit and a GPS, constructing a map by utilizing SLAM software according to the data, and calculating the pose of a mobile robot in real time; acquiring following target information through a binocular vision module, and calculating a target pose in real time according to the following target information; and calculating a global optimal route according to the target pose and the pose of the mobile robot to automatically avoid static obstacles, and providing linear velocity and angular velocity instructions based on the global optimal route. The following target information is determined according to the specific gesture of the person, the tracking of the non-cooperative target is achieved, and the global optimal route is calculated, so that the static obstacles are automatically avoided.
Owner:BEIJING MECHANICAL EQUIP INST
Printed flexible circuit (PFC) voltage following circuit
InactiveCN108880223AReduce shockExtend your lifeEfficient power electronics conversionPower conversion systemsFlexible circuitsComputer module
The invention provides a printed flexible circuit (PFC) voltage following circuit. A PFC voltage following module is employed, an input voltage is detected in real time, an output voltage is adjustedaccording to a detection result, the output voltage is reduced when the input voltage is relatively low, and the output voltage changes with the input voltage. The PFC voltage following circuit is simple in structure and is low in cost. The voltage following circuit is formed on the basis of a traditional mature PFC circuit, so that the PFC voltage following is achieved; and the output voltage issynchronously adjusted to a relatively low value when the input voltage is relatively low, so that the impact to a switch power device for achieving voltage conversion is effectively reduced, the lifetime of the power device can be prolonged, and the integral working efficiency of a power supply is improved.


Owner:杭州益川电子有限公司
A fully automatic intelligent following luggage cart
InactiveCN106965835BFollow implementationAvoid cumbersomeSledge wheelsPosition/course control in two dimensionsDrive wheelControl engineering
The invention discloses a full-automatic intelligent following luggage car capable of achieving following operation according to a given trajectory. The full-automatic intelligent following luggage car comprises a luggage car body and a following system. The luggage car body comprises a main car body and a roller device arranged on the lower portion of the main car body and distributed in a triangle mode. The roller device is composed of a drive wheel arranged on the front of the lower portion of the main car body, and driven wheels symmetrically arranged on the two sides of the rear side of the lower portion of the main car body. A drive mechanism is arranged inside the main car body. The following system comprises a signal emitting device and a signal receiving device. The signal receiving device is sequentially connected with a central processor and a logic arithmetic unit. The logic arithmetic unit is connected with the drive mechanism and a steering mechanism. By adopting the following system to control movement of the main car body, following of the luggage car and a user is achieved on the premise that the user does not perform any operation on the luggage car, and troubles and labor waste caused by purely manual pushing of the car are avoided.


Owner:SICHUAN COLLEGE OF ARCHITECTURAL TECH
Target object following method for mobile robot based on monocular vision sensor
ActiveCN109166136BFollow implementationFollow validImage enhancementImage analysisEngineeringVisual recognition
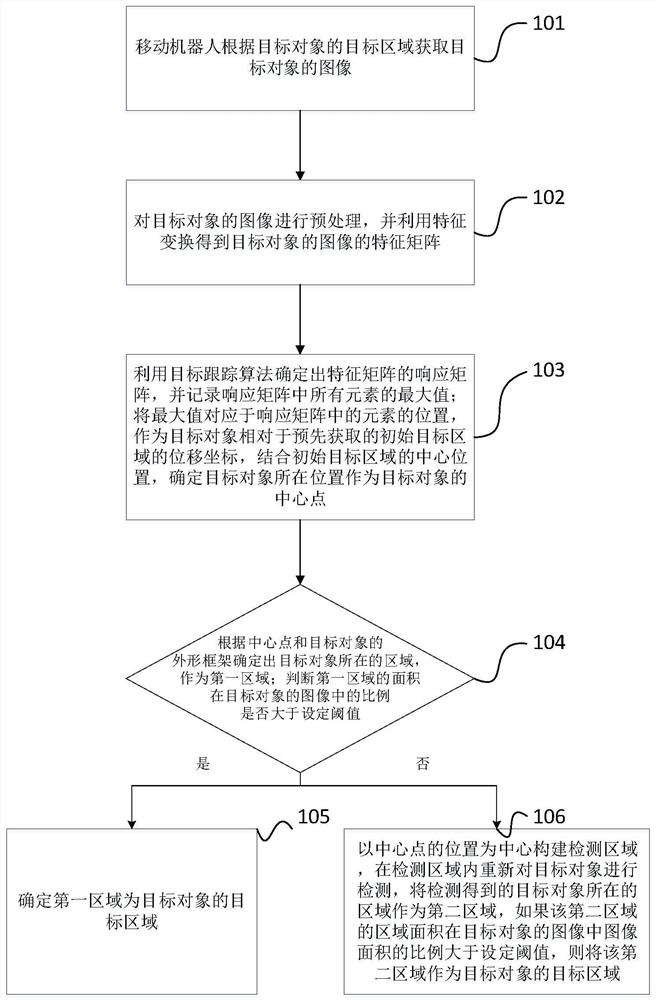
The present invention relates to the field of computer vision recognition, and specifically provides a method for following a target object of a mobile robot based on a monocular vision sensor, aiming to solve the problem that the existing mobile robot has poor robustness in following the target object, and it is difficult to ensure the following target objects such as pedestrians quality problem. For this purpose, the method that the present invention provides comprises that mobile robot acquires the image of the target object according to the target area of the target object; Obtain the feature matrix of the image of the target object; Utilize the target tracking algorithm and the feature matrix to determine the center point of the target object; According to the center point and the outline frame of the target object to determine the area where the target object is located as the first area, judge whether the proportion of the area of the first area in the image of the target object is greater than a set threshold, and perform corresponding operations according to the judgment result. Based on the above steps, the method provided by the present invention has good real-time performance and robustness, and can effectively follow the target object.
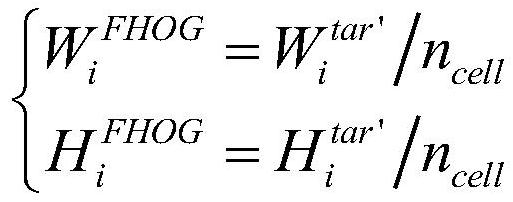
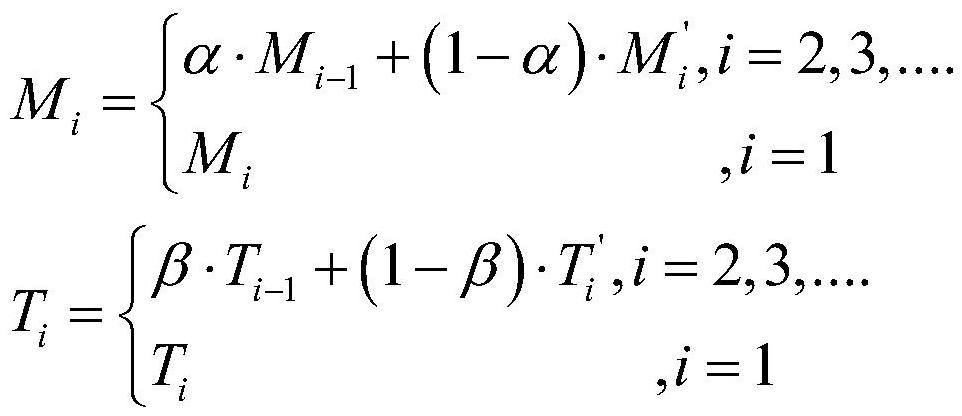
Owner:INST OF AUTOMATION CHINESE ACAD OF SCI