

Patents
Literature
8results about How to "Improve masonry quality" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Bracket structure for chute area of dry quenching furnace
PendingCN113755187AImprove masonry qualityExtended service lifeCoke quenchingMortar jointStructural engineering
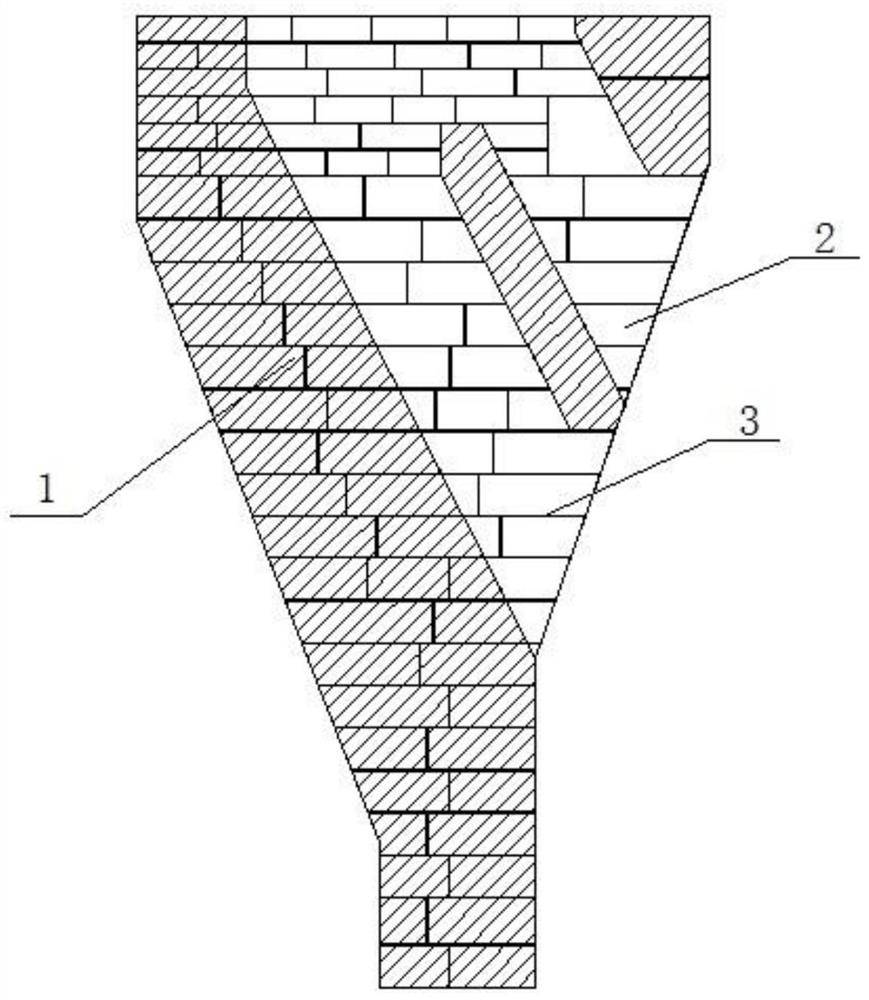
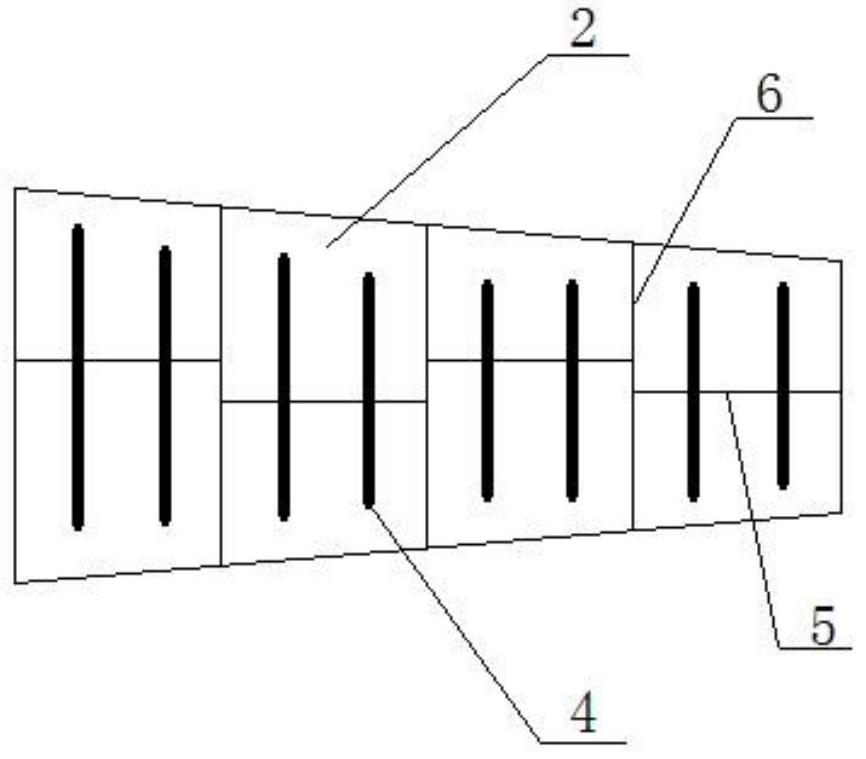
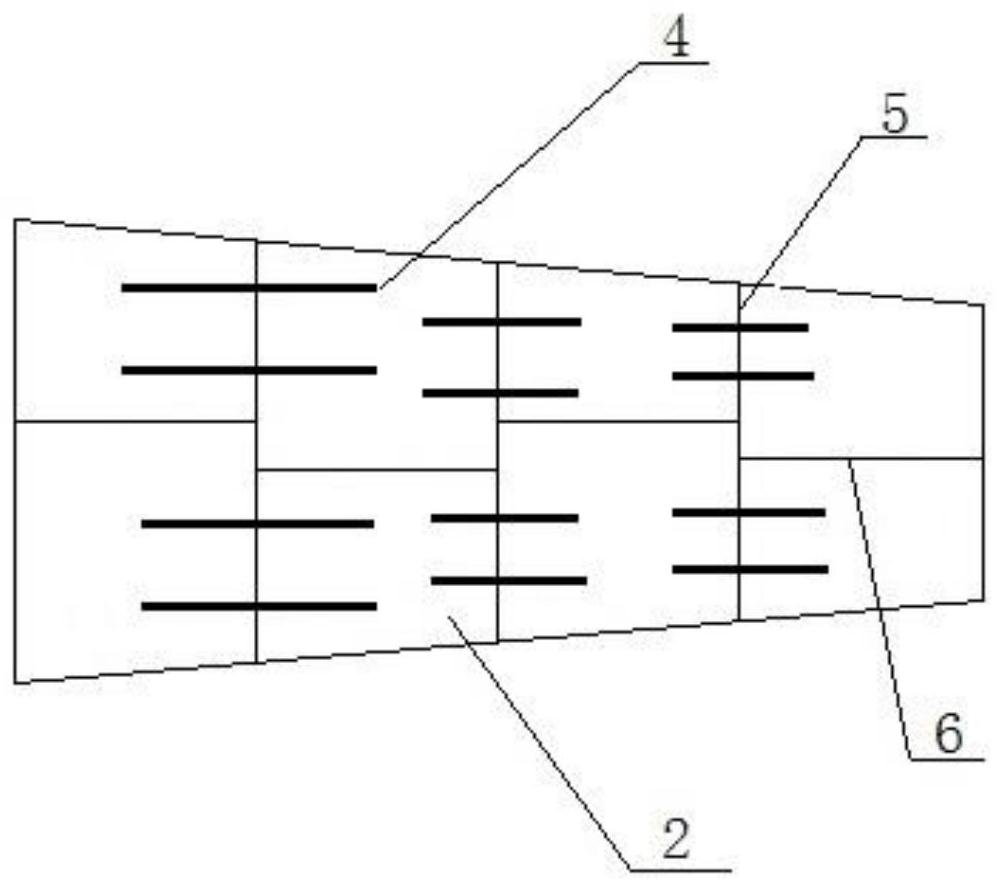
The invention relates to a bracket structure for a chute area of a dry quenching furnace. The bracket structure is formed by building a plurality of layers of bracket bricks; and a plurality of supporting pieces are arranged between every two adjacent layers of bracket bricks, the supporting pieces are hard supporting pieces, the thickness of the supporting pieces is the same as that of mortar joints, the top faces of the supporting pieces make direct contact with the upper layer of bracket bricks, and the bottom faces of the supporting pieces make direct contact with the lower layer of bracket bricks. The supporting pieces are placed in the refractory mortar joints between the bracket brick layers, so that the problems of sinking of the annular air duct and cracking of the chute partition wall caused by deformation of the bracket mortar joints and inaccurate bracket elevation control are effectively prevented, the masonry quality of the dry quenching furnace is improved, and the service life of the dry quenching furnace is prolonged.
Owner:ACRE COKING & REFRACTORY ENG CONSULTING CORP DALIAN MCC
Integrated high-performance lining brick for converter and preparation method thereof
ActiveCN116411149Bfulfil requirementsimprove integrityManufacturing convertersProcess efficiency improvementTunnel kilnConverters
The present invention discloses an integrated high-performance lining brick for a converter and a preparation method thereof, which belongs to the technical field of refractory materials for steel smelting converters, and comprises a brick body, wherein the brick body comprises a permanent layer of magnesium bricks and a working layer of magnesium carbon bricks, wherein the permanent layer of magnesium bricks and the working layer of magnesium carbon bricks are connected by a slot structure. The preparation method comprises the following steps: weighing each raw material; mixing and secondary molding operation; drying the integrated lining brick blank of the working layer of magnesium carbon bricks and the permanent layer of magnesium bricks to obtain an integrated high-performance lining brick for the converter. The integrated high-performance lining brick of the present invention can simplify the masonry process, greatly shorten the masonry time, complete the masonry task within the specified time, meet the requirements of the steel plant, and improve the integrity of the refractory material of the converter lining. The present invention has a simple production process, no high-temperature firing process, gets rid of the dependence on high-temperature tunnel kilns, etc., reduces manufacturing costs, saves resources, responds to the national call for energy conservation and emission reduction, and is beneficial to environmental protection.

Owner:ANSHAN HEFENG REFRACTORY MATERIAL CO LTD
A bracket structure for the chute area of a dry quenching coke oven
ActiveCN113755187BImprove masonry qualityExtended service lifeCoke quenchingStructural engineeringCoke oven
The present invention relates to a corbel structure of a chute area of a dry quenching coke oven, wherein the corbel structure is constructed by masonry of multiple layers of corbel bricks; a plurality of support members are arranged between two adjacent layers of corbel bricks, wherein the support members are hard support members, the thickness of which is the same as the thickness of the mortar joints, the top surface of the support members is in direct contact with the upper layer of corbel bricks, and the bottom surface of the support members is in direct contact with the lower layer of corbel bricks. The present invention effectively prevents the sinking of an annular air duct and the cracking of a chute partition wall caused by deformation of the corbel mortar joints and inaccurate control of the corbel elevation, thereby improving the masonry quality and service life of the dry quenching coke oven.

Owner:ACRE COKING & REFRACTORY ENG CONSULTING CORP DALIAN MCC
Forming die of burner block for coke oven
ActiveCN222003859Ureduce crackingIncreasing the thicknessCeramic shaping mandrelsCeramic shaping coresBrickCombustion chamber
The utility model belongs to the technical field of forming of burner bricks for coke ovens, and discloses a forming die for burner bricks for coke ovens, which is characterized in that a forming cylinder is hollow and circular, and a lower cover plate is mounted at the bottom of a forming cylinder body; the upper cover plate is installed on the upper portion of the forming cylinder body, the core penetrates through the core hole, the lower cylinder cavity, the conical cavity, the transition conical cavity, the upper cylinder cavity and the first core hole from bottom to top and extends to the upper portion of the forming cylinder body, and the diameter of the upper end of the core is smaller than that of the lower end of the core. The burner block has the beneficial effects that 1, the problem of cracking of the burner block due to long-term high-temperature environment is reduced; and 2, the diameter ratio of the central through hole of the burner block is reduced, the thickness of the burner block body is increased, the high-temperature erosion resistance of the burner block body is improved, and the service life of the burner block body is prolonged. And 3, the contact area between the burner block and the refractory lining body of the combustion chamber of the coke oven during masonry is increased, so that the bonding strength of the masonry of the burner block is improved, and the masonry quality of the burner block is improved.

Owner:LUOYANG MAILE REFRACTORY CO LTD
Wall building robot grabbing identification method and system fusing BIM and visual observation information
ActiveCN119152028Aincrease autonomyincrease flexibilityImage analysisImage generationBrickUndirected graph
The invention provides a wall building robot grabbing identification method and system fusing BIM and visual observation information, and belongs to the field of robot grabbing, and the method comprises the steps that S1, a wall building robot obtains building instruction information, determines a to-be-built brick type and the position of the to-be-built brick type in an overall building task, obtains a BIM model of the to-be-built brick type from a BIM model library, and stores the BIM model of the to-be-built brick type in the overall building task; extracting geometric and semantic information of the to-be-built brick type; s2, building a brick layout undirected graph based on the BIM model of the overall masonry task, carrying out a collision test, and determining candidate grabbing positions meeting masonry requirements according to a result of the collision test; s3, the wall building robot collects three-dimensional point cloud data of the target scene, analyzes the three-dimensional point cloud data and determines the main axis direction and size characteristics of the target brick; s4, performing information fusion analysis on the geometric and semantic information of the to-be-built brick type and the main axis direction and size characteristics of the target brick to obtain a grabbing rectangular frame of the target brick; and S5, the grabbing rectangular frame is projected to a two-dimensional image screen, grabbing pose parameters of the wall building robot are calculated, and the wall building robot executes brick grabbing according to the grabbing pose parameters. By constructing the brick layout undirected graph and the collision test, the reasonability and the safety of the grabbing position are ensured, and meanwhile, the autonomy, the flexibility and the working efficiency of the wall building robot are remarkably improved.

Owner:WUHAN UNIV OF SCI & TECH +1
Circumferential scanning detection mechanism and automatic masonry equipment
ActiveCN222013016Uimprove accuracyEliminate the effects ofPhotogrammetry/videogrammetryUsing optical meansMachine controlControl system
The utility model provides an annular scanning detection mechanism and automatic masonry equipment. The annular scanning detection mechanism comprises an annular guide rail, a rotating part, a scanning camera, a first driving part and a second driving part, the annular guide rail is used for annularly sleeving the machine body stand column and is in up-down sliding connection with the machine body stand column. The rotating piece is slidably connected to the annular guide rail in the circumferential direction of the annular guide rail; the scanning camera is fixedly connected to the rotating part, the scanning end faces the periphery of the annular guide rail, and the scanning camera is electrically connected with the complete machine control system and transmits scanning data to the complete machine control system. The output end of the first driving part is in transmission connection with the machine body stand column and used for driving the annular guide rail to move up and down; the second driving part is arranged on the annular guide rail, and the output end is in transmission connection with the rotating part and used for driving the scanning camera to annularly move along with the rotating part. The circumferential scanning detection mechanism provided by the utility model can improve the efficiency and quality of masonry construction.

Owner:TANGSHAN YINGLAI TECH CO LTD
Horizontal mortar laying device for masonry
ActiveCN222350289UGuaranteed uniformitygood lookingBuilding material handlingClassical mechanicsStructural engineering
The utility model relates to a horizontal masonry mortar laying device which comprises two longitudinal side face positioning rods, two longitudinal coping positioning rods and two transverse connecting rods, and the two longitudinal side face positioning rods are arranged side by side in the left-right direction and in the front-back direction. The two longitudinal coping positioning rods are in one-to-one correspondence with the two longitudinal side surface positioning rods, the longitudinal coping positioning rods are arranged on the upper sides of the corresponding longitudinal side surface positioning rods and are in the front-back direction, and the tops of the longitudinal side surface positioning rods are detachably connected with the outer side parts of the longitudinal coping positioning rods; the two transverse connecting rods are arranged on the upper sides of the two longitudinal side face positioning rods side by side front and back, the transverse connecting rods are in the left-right direction, and the transverse connecting rods are detachably connected with the two longitudinal side face positioning rods. According to the horizontal mortar laying device for the masonry, a worker can conveniently conduct construction on the upper portion of the constructed masonry so as to form horizontal mortar joints which are filled compactly and uniform in thickness, the construction quality of the masonry mortar joints can be better guaranteed, and the appearance of the masonry mortar joints of a masonry wall and the masonry quality can be improved.

Owner:GUANGDONG NO 2 CONSTR ENG CO LTD
Adjustable building hoist wall attaching frame
ActiveCN222118567Ureduce installationEfficient transportElevatorsArchitectural engineeringStructural engineering
The utility model discloses an adjustable wall-attached frame of a construction hoist, which is mounted in an attached scaffold and comprises a main frame fixed with the attached scaffold; the connecting rod is connected with the main frame and is detachably connected with the main body structure; the adjusting mechanism and the main frame are adjustably installed, and the adjusting mechanism and the construction hoist guide rail frame are detachable; locking and unlocking between the wall attaching frame and the main body structure and between the wall attaching frame and the construction hoist guide rail frame are achieved through the connecting rod and the adjusting mechanism before and after the attached scaffold is lifted. The wall-attached frame has the advantages that the wall-attached frame can be installed on an attached scaffold, and installation of temporary wall-attached frames is reduced through recycling. And meanwhile, a construction hoist can enter two layers of the bottom of the attached scaffold, materials can be effectively transported to a working face, synchronous engineering construction is completed, a backhand wall is avoided, the building quality is greatly improved, the vertical transportation pressure is reduced, and more excellent conditions are provided for hoisting of components.

Owner:SHANGHAI URBAN CONSTRUCTION MUNICIPAL ENGINEERING (GROUP) CO LTD