

Patents
Literature
52results about How to "Improve attitude control accuracy" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Spatial multidimensional micro-vibration simulator based on six-dimensional parallel mechanism
InactiveCN105415349AOvercoming modal lowGet over workProgramme-controlled manipulatorEngineeringMaximum amplitude
The invention relates to a spatial multidimensional micro-vibration simulator based on a six-dimensional parallel mechanism, in particular to a parallel mechanism based on the Stewart-Gough platform. The spatial multidimensional micro-vibration simulator comprises an upper platform, a lower platform and six driving legs, wherein the upper platform and the driving legs are connected through spherical hinges; the lower platform and the driving legs are connected through hook joints; the driving legs are composed of components like voice coil motors, leaf springs and stop sleeves, and can output vibration with the maximum amplitude of 3 mm and the maximum frequency of 500 Hz in the axial direction. According to the spatial multidimensional micro-vibration simulator based on the six-dimensional parallel mechanism, provided by the invention, by adjusting expansion and contraction of the six driving legs to control the six-dimensional motion of the upper platform and the load thereof, the simulation of spatial micro-vibration can be completed; the vibration mode output by the simulator is multidimensional random vibration with specific spectrum form, the effective bandwidth is 0.5-100 Hz, and the shock excitation magnitude is 10<-5> g-10<-3>g.


Owner:CHANGCHUN INST OF OPTICS FINE MECHANICS & PHYSICS CHINESE ACAD OF SCI
Method and system for controlling satellite from any attitude to sun pointing attitude
ActiveCN106864774AImprove attitude control accuracyOrientation towards the sunCosmonautic vehiclesSpacecraft guiding apparatusAngular velocityEnergy supply
The invention discloses a method for controlling a satellite from any attitude to a sun pointing attitude. The method for controlling the satellite from any attitude to the sun pointing attitude comprises the steps of measuring inertial angle increment by using an inertial reference unit; differentiating the inertial angle increment to obtain inertial angular velocity; measuring the specific direction of the satellite where the sun appears by using a 0-1 type sun sensor and carrying out sun acquisition to obtain a sun direction signal; controlling satellite attitude acquisition by using the change of the sun direction signal; and reducing an included angle between sun vector and one axis of the satellite so as to carry out sun pointing. By using the sun direction information of the 0-1 type sun sensor, the sun can be acquired; and through the change of the sun direction signal, the satellite can be controlled to point the sun to provide satellite guarantee for energy supply of the whole satellite; and beneficial effects of realizing the satellite from any attitude to the sun pointing attitude only by using the inertial reference unit and the 0-1 type sun sensor, improving the satellite attitude control accuracy and so on are achieved.


Owner:SHANGHAI AEROSPACE CONTROL TECH INST
Flexible satellite adaptive neural network sliding mode attitude control method
ActiveCN104898418ASuitable for engineering applicationsImprove anti-interference abilityAdaptive controlDynamic modelsDynamic equation
Provided is a flexible satellite adaptive neural network sliding mode attitude control method. The invention relates to a flexible satellite adaptive neural network sliding mode attitude control method. The invention provides a flexible satellite adaptive neural network sliding mode attitude control method to solve the problem that the attitude of a flexible satellite fluctuates due to modal vibration of a panel and rotation of an antenna and the reduction of system stability is caused thereby. The method comprises the following steps: step 1, establishing a flexible satellite attitude dynamics model; step 2, obtaining a simplified flexible satellite attitude dynamics equation; step 3, designing a sliding mode attitude controller with use of an RBF neural network according to the simplified flexible satellite attitude dynamics equation; and step 4, further using an RBF neural network approximation sign function eta'sgn(s) to weaken the influence of buffeting to the sliding mode attitude controller so as to obtain a buffeting-weakened sliding mode attitude controller. The flexible satellite adaptive neural network sliding mode attitude control method of the invention is applied to the field of flexible satellite attitude control.


Owner:HARBIN INST OF TECH
Yaw attitude control method of multi-axis maneuver imaging satellite with ellipticity of the earth considered
ActiveCN103941740AImprove attitude control accuracyMeet the needs of useAttitude controlNatural satelliteEarth's rotation
According to a yaw attitude control method of a multi-axis maneuver imaging satellite with ellipticity of the earth considered, satellite rolling and attitude maneuver conducted in pitching are considered, misalignment of an optical axis of optical load and a collimation axis of the optical load are also considered, and the defect that a traditional control method can be adapted only to satellite side wing maneuver and the optical axis is aligned with the collimation axis is overcome. In the process of obtaining a linear speed of a ground target point relative to a satellite, the speed is divided into three parts of a linear speed caused by earth rotation, a satellite orbit operation speed and an operation speed of the ground target point relative to the satellite caused by satellite orbit angular velocity. In the solving process of the satellite optical axis pointing to a ground target point vector, the rotating ellipsoid feature of an actual earth model is considered, coordinate transformation is introduced, simpleness and convenience of the method are guaranteed, and obtaining of high precision drift angle attitude is achieved. The yaw attitude control method of the multi-axis maneuver imaging satellite with ellipticity of the earth considered is suitable for simultaneous maneuver of the multi-axis of the satellite, and meets the usage requirements of most high precision to-earth imaging satellites at present.


Owner:BEIJING INST OF CONTROL ENG
Space-based large-diameter multi-constrained extrasolar terrestrial planet detector structure
InactiveCN106428651ALow center of massImprove attitude control accuracyCosmonautic vehiclesCosmonautic partsObservational errorGas cylinder
The invention provides a space-based large-diameter multi-constrained extrasolar terrestrial planet detector structure. The structure comprises a platform service module, a platform propelling module, a payload, a star sensor and a platform bottom plate; the back light path part of the payload is embedded into the platform service module, the star sensor is installed on a high-rigidity back plate of the payload, therefore, the attitude measuring error is decreased, and the attitude control precision of a whole detector is improved; intra-detector subsystem single units of the detector are arranged on the obverse side of the platform bottom plate, and thrusters and air cylinders are arranged on the reverse side of the platform bottom plate. According to the space-based large-diameter multi-constrained extrasolar terrestrial planet detector structure, by means of integrated design of a load platform, the mass center of the whole detector can be lowered, and the enveloping limiting requirement of a launch vehicle fairing can be met; meanwhile, attitude sensitive devices such as the star sensor are arranged on the high-rigidity back plate of the payload, therefore, the attitude measuring error can be decreased, and the attitude control precision of the whole detector can be improved. The structure can be effectively applied to layout design of a similar detector structure with a large-diameter multi-constrained space camera.


Owner:SHANGHAI SATELLITE ENG INST
Flexible satellite active vibration suppression method based on component force synthesis and fixed time convergence
ActiveCN110733668ASuppression of elastic vibrationsImprove attitude control accuracyCosmonautic vehiclesSustainable transportationLoop controlDynamic models
The invention discloses a flexible satellite active vibration suppression method based on component force synthesis and fixed time convergence. The flexible satellite active vibration suppression method comprises the following steps of step 1, establishing a flexible satellite attitude dynamics model with two pairs of large solar panels, and simultaneously establishing a dynamic model of a piezoelectric intelligent material actuator; step 2, designing a fixed time convergence sliding mold controller; step 3, designing a disturbance observer for ensuring a double-layer self-adaptive law with fixed time convergence characteristics; and step 4, outputting a dynamic model of the piezoelectric intelligent material actuator, implementing processing by adopting a continuous component force synthesis control idea, generating a new control torque command to be applied to a flexible accessory to counteract the influence of elastic vibration, and ensuring the attitude stability of a satellite body. The flexible satellite active vibration suppression method has the advantages of high attitude control precision and strong robustness. Meanwhile, a continuous component force synthesis method is introduced into a closed-loop control process through a piezoelectric sheet attached to the flexible accessory, vibration is inhibited, and the system interference is reduced.
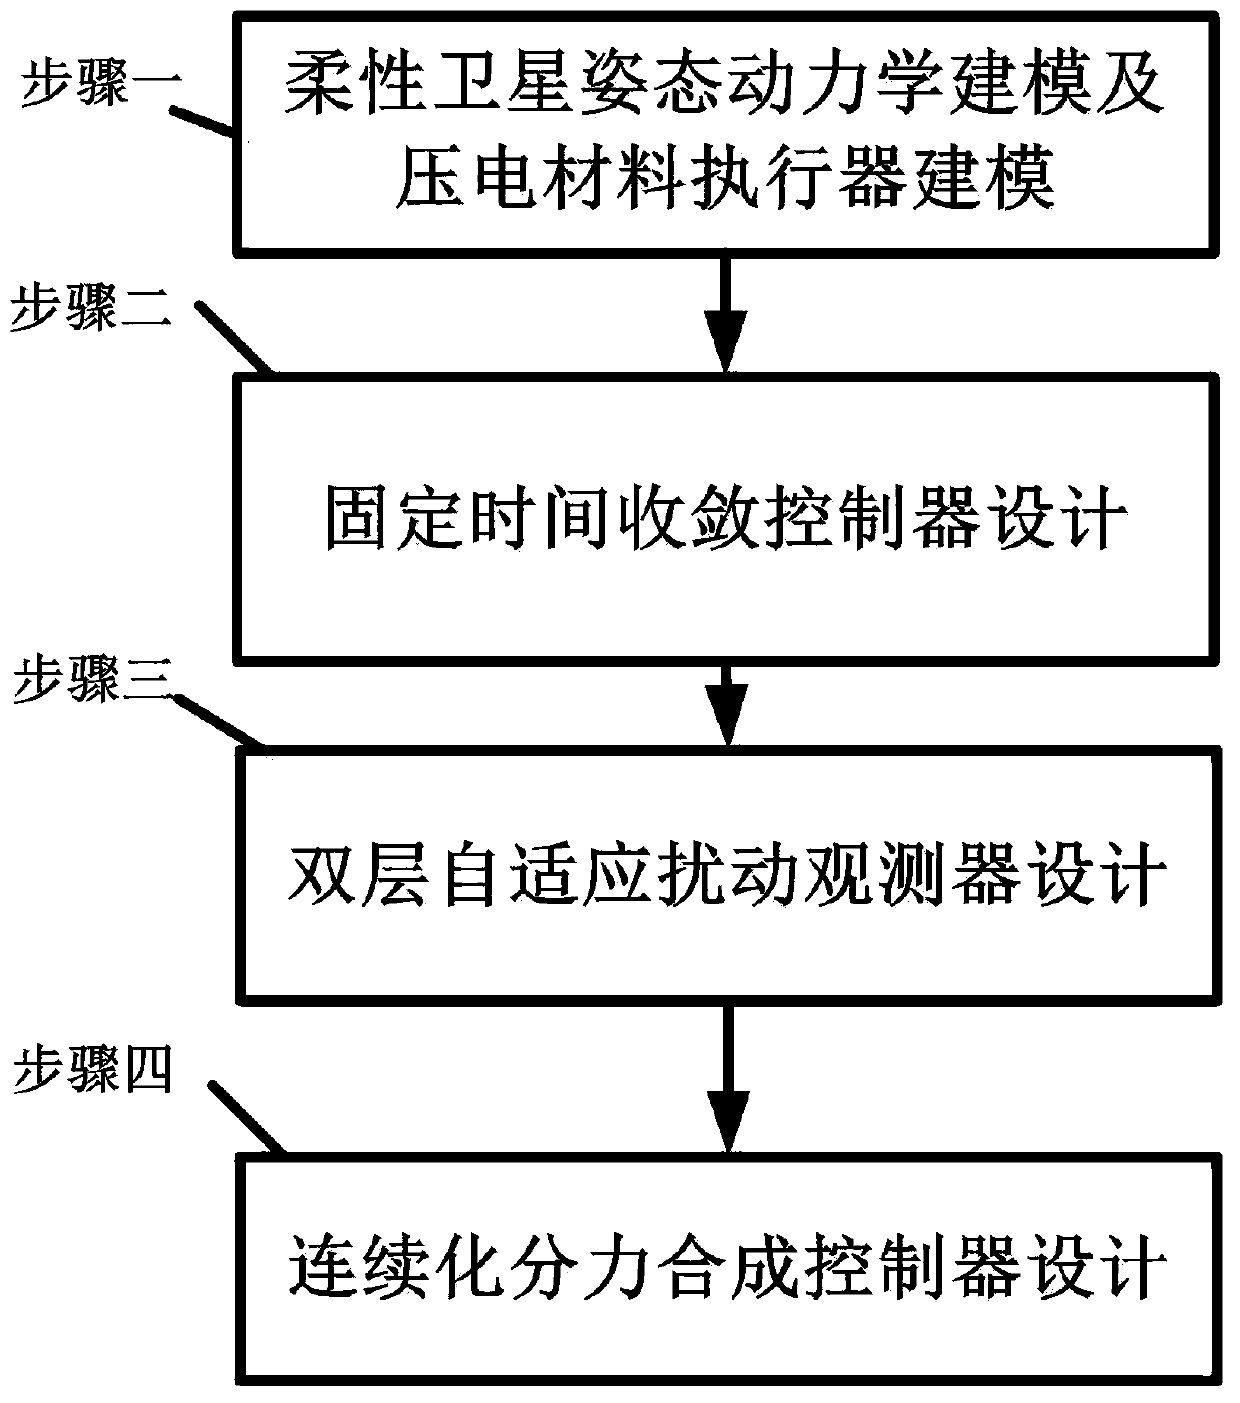
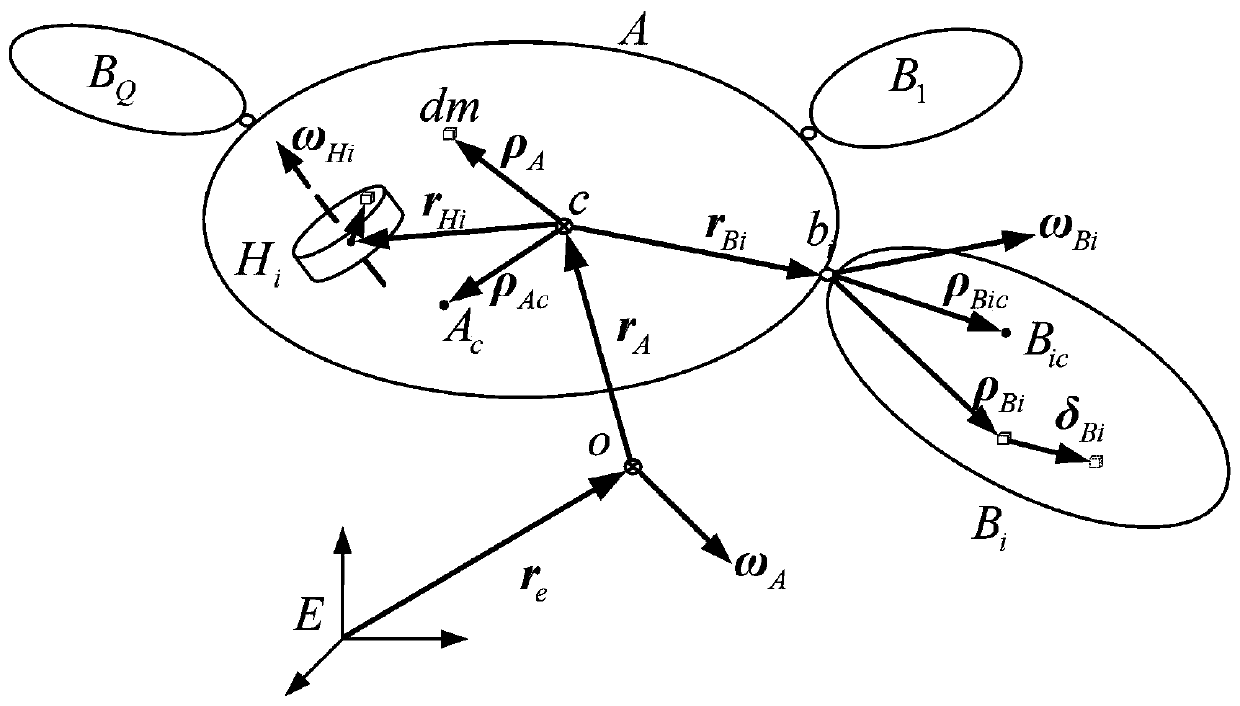
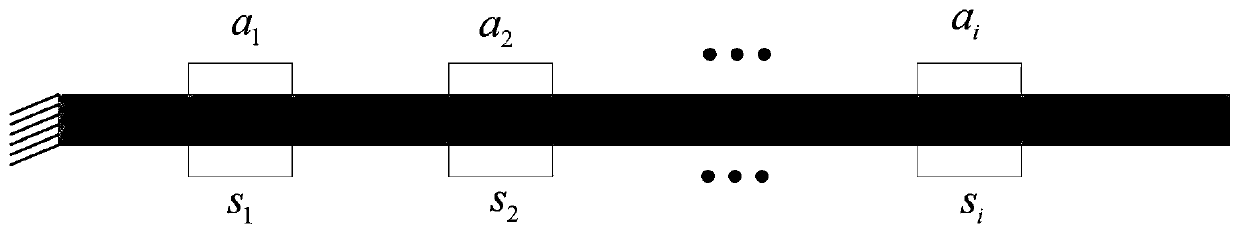
Owner:SUN YAT SEN UNIV
Four-rotor aircraft attitude control method and controller
ActiveCN109885077AImprove attitude control accuracySolving Numerical Instability ProblemsAttitude controlPosition/course control in three dimensionsNumerical stabilityAttitude control
The invention discloses a four-rotor aircraft attitude control method and controller. For the disadvantage that a four-rotor aircraft system is difficult to establish a precise physical model, the nonlinear dynamic characteristic of the system is described by establishing a RBF-ARX model, which is locally linear and globally nonlinear, by adopting a system identification method; for the characteristic of the model and to satisfy quick response characteristic and relatively high control performance requirements of the system, the model is converted into a non-minimum state space model having anintegration link at first; then, a prediction controller is designed; furthermore, input is parameterized by using a laguerre function; therefore, predictive control of the online optimization variable of the system is reduced; furthermore, a given reference signal can be precisely tracked; and, for the numerical stability problem due to increasing of a prediction time domain, an exponential decay weight is introduced into a target function, so that a closed-loop system has the specified stability. The scheme has the characteristics of being short in online optimization time and steady in numerical value in a relatively large prediction time domain condition, and has relatively high practical value and application prospect.
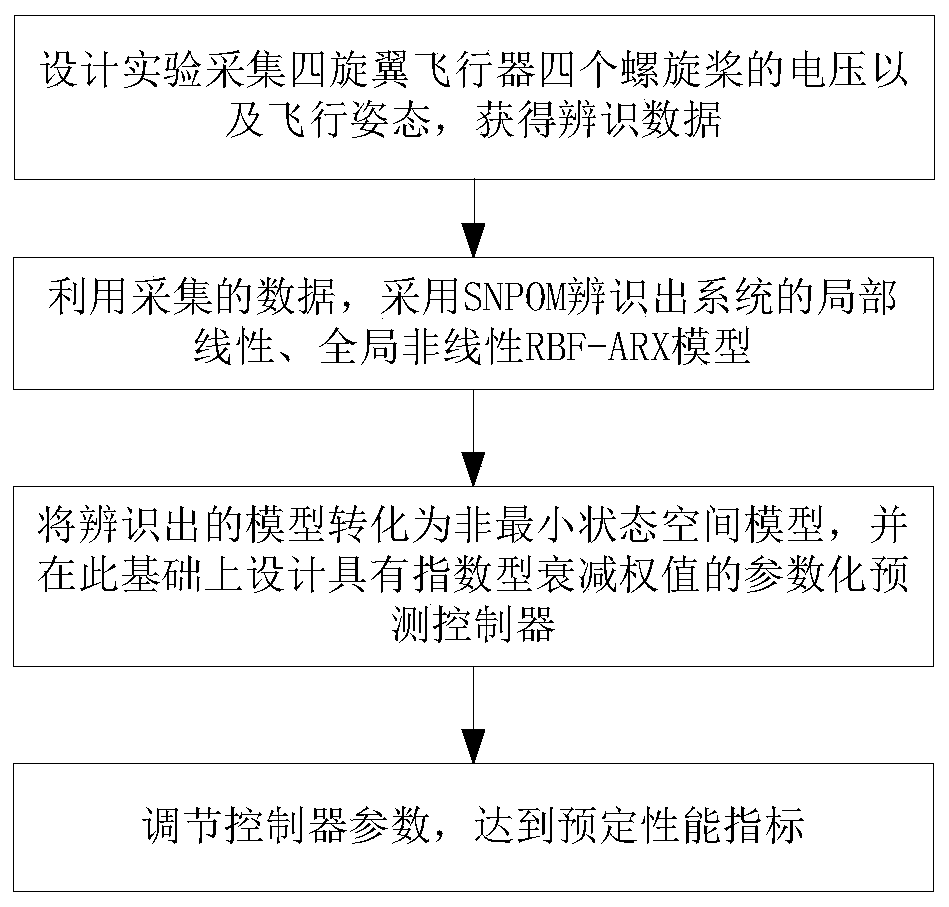
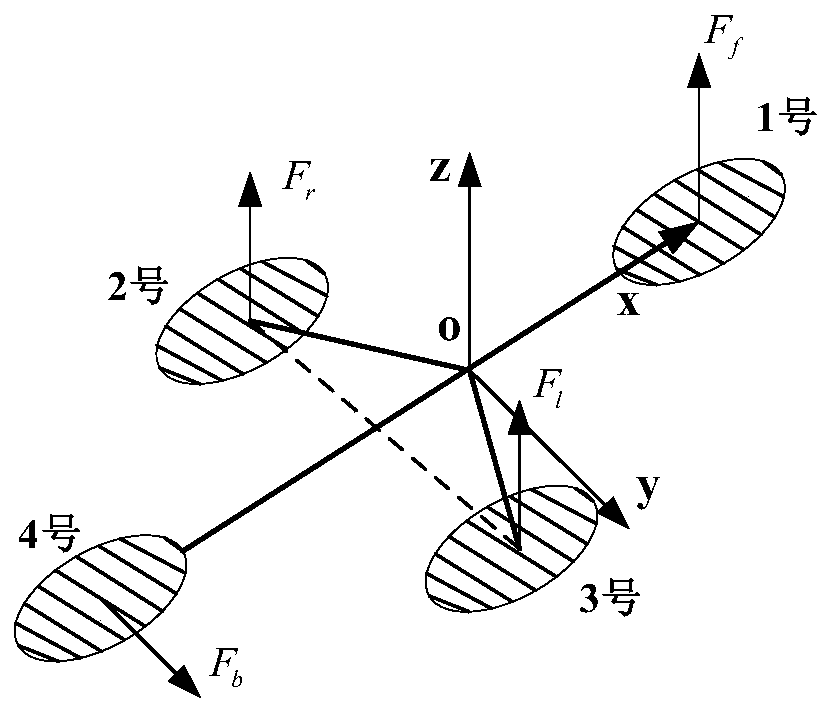
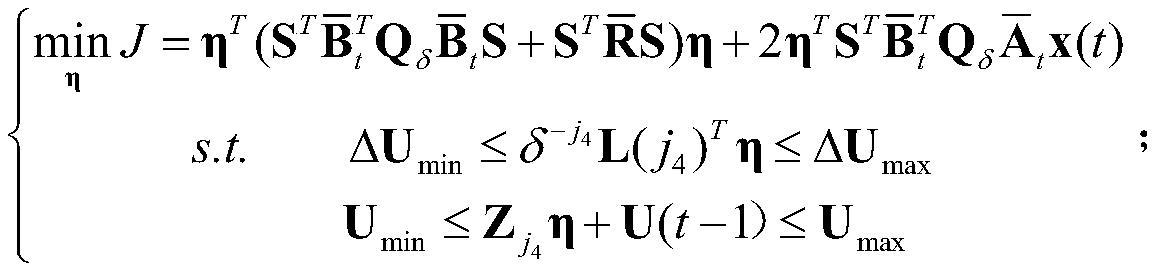
Owner:CENT SOUTH UNIV
Rapid spacecraft disturbance torque on-orbit closed-loop identification method, system and medium
ActiveCN108279695AAdjust the convergence rateFast convergenceCosmonautic vehiclesCosmonautic partsGyroscopeAttitude control
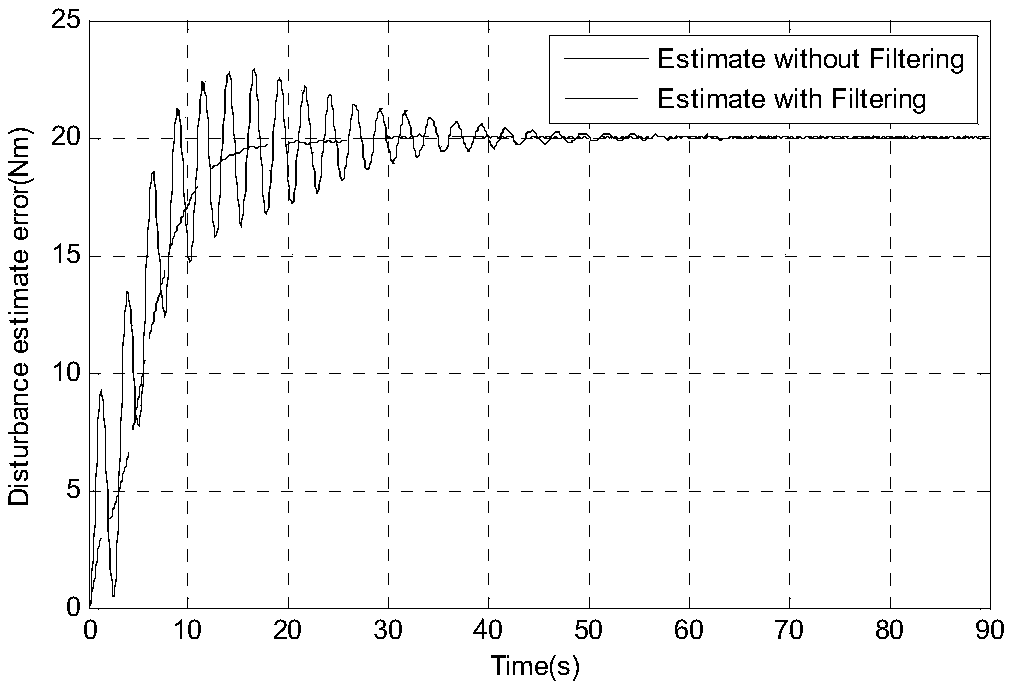
The invention discloses a rapid spacecraft disturbance torque on-orbit closed-loop identification method, system and medium, and provides a rapid orbital transfer disturbance torque closed-loop identification method to solve the attitude control problem of a spacecraft with flexural vibration and liquid sloshing in orbital transfer during ignition of a main engine. The method includes the steps: (1) integrating angular speed measured by a gyroscope to obtain an attitude angle and calculating needed control quantity by a controller; (2) inputting data to a disturbance estimation equation according to attitude angle input and the calculated control quantity to obtain a preliminary estimation value of disturbance torque; (3) further inputting the preliminary estimation value of the disturbance torque to a filter, and filtering low-frequency flexural and liquid sloshing information to obtain final disturbance estimation values. By the method, when flexural vibration and liquid sloshing arepresent, the disturbance torque can be rapidly and accurately identified. Disturbance identification results can be directly fed forward to an integral term, so that attitude overshoot caused by start of the main engine can be decreased.
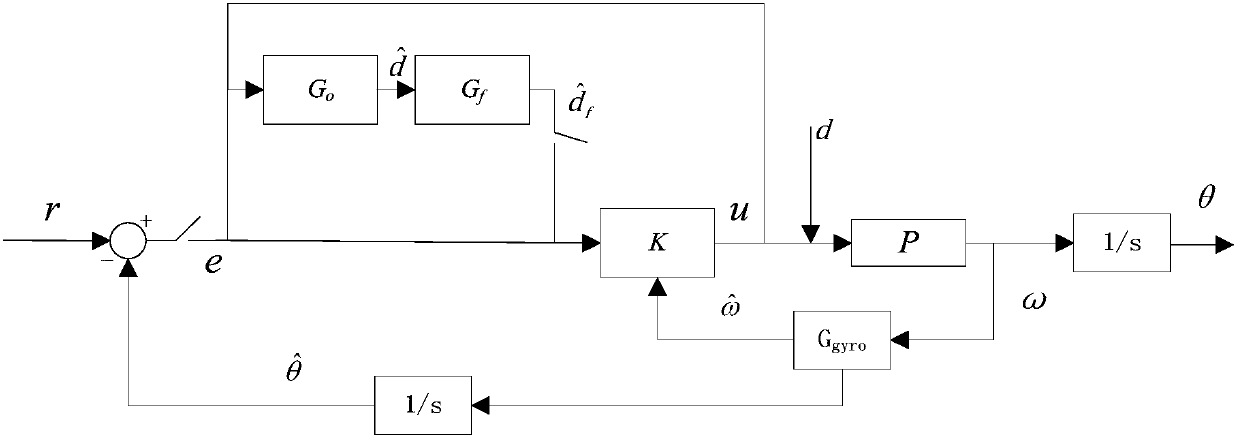
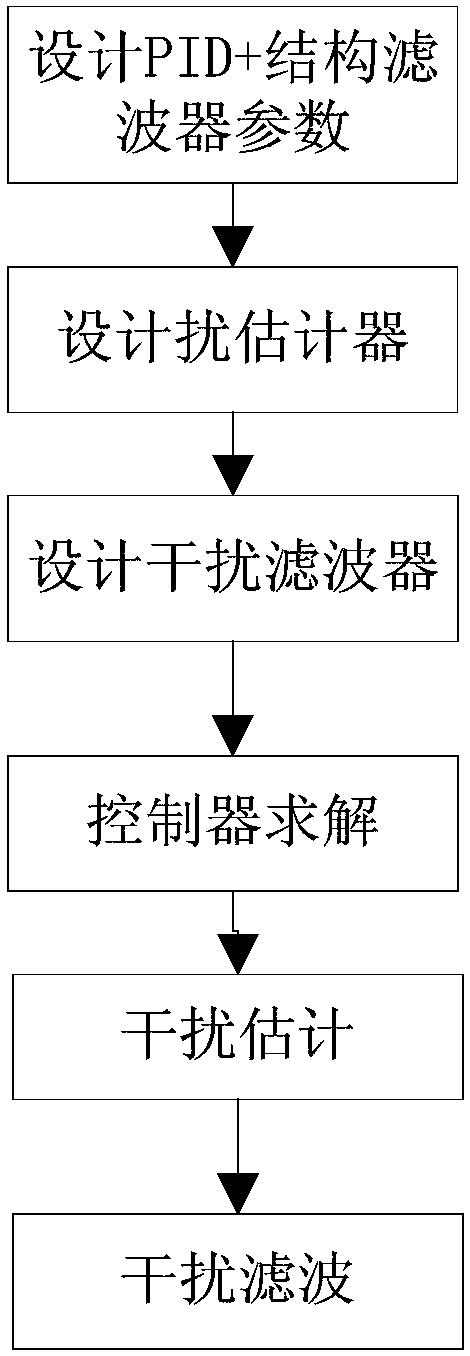
Owner:BEIJING INST OF CONTROL ENG
Novel anti-interference attitude control circuit resolving system
ActiveCN103885451AReduced attitude control accuracyImprove attitude control accuracyAttitude controlAviationEarth observation
The invention relates to a novel anti-interference attitude control circuit resolving system. The hardware part of the system is composed of an embedded microprocessor, a storer unit, a reset unit, a communication unit, an expansion power supply unit, a power supply unit, a clock unit, an expansion I / O unit and a debugging unit. An anti-interference attitude control algorithm contained in the algorithm part of the system relates to a disperse interference observer and a feedback controller, the disperse interference observer conducts real-time estimation and counteraction on interference such as execution vibration which can be modeled and exists in the system firstly, and then the feedback controller correspondingly restrains interference such as spiral environment torque which can not be modeled and exists in the system. According to the software and hardware integrated type attitude control circuit resolving system, a hardware circuit is simple in structure, communication can be achieved conveniently and quickly, the control algorithm can be used for counteraction and restraining on different types of interference, and attitude control accuracy and stability of the system can be improved. The system is especially suitable for tasks such as high-resolution earth observation and remotely-sensed imaging in the aerospace field.


Owner:BEIHANG UNIV
Multi-degree-of-freedom spherical electric magnetic levitation momentum wheel
ActiveCN109229424AReduced mechanical propertiesReduce wearCosmonautic vehiclesMagnetic holding devicesRotational axisSpatial Orientations
The invention provides a multi-degree-of-freedom spherical electric magnetic levitation momentum wheel, which is composed of an external support assembly, a spherical driving motor and an internal electric magnetic levitation momentum wheel. The outer support assembly locates and fixes the stator of the spherical drive motor and provides spherical support for the spherical mover. Sinusoidal alternating current with different phases is introduced into the stator coil array of the spherical drive motor to form traveling wave magnetic field with different directions, which can drive the whole spherical mover to change its spatial orientation, and then the spatial orientation of the maglev momentum wheel rotating shaft can be adjusted in a large range. At the same time, according to the principle of electric drive, the momentum wheel of internal electric magnetic suspension is driven by both stable suspension and rotating around the axis, so as to realize the complete control of the rotational axis direction and rotational speed of the momentum wheel of internal magnetic suspension, and finally realize the multi-axis active control of the attitude of the spacecraft.


Owner:TSINGHUA UNIV
Last stage orbit remaining application subsystem attitude control method
ActiveCN109573105AEliminate the effect of time lagImprove attitude control accuracyCosmonautic vehiclesSpacecraft guiding apparatusController designTime lag
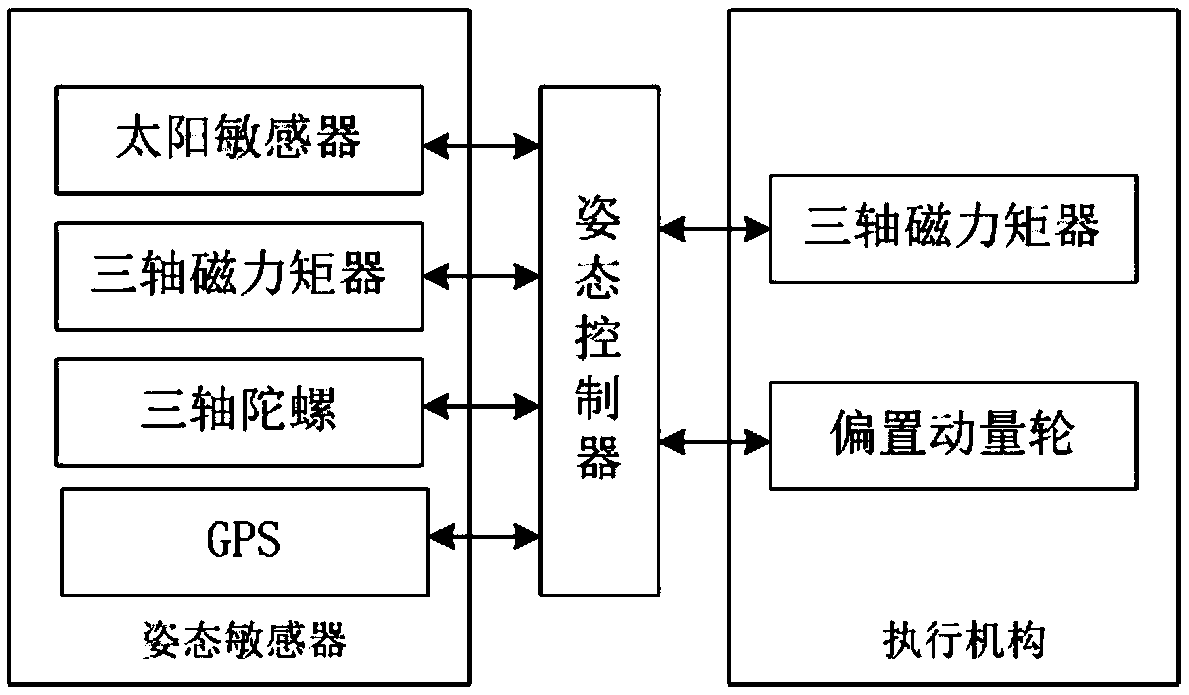
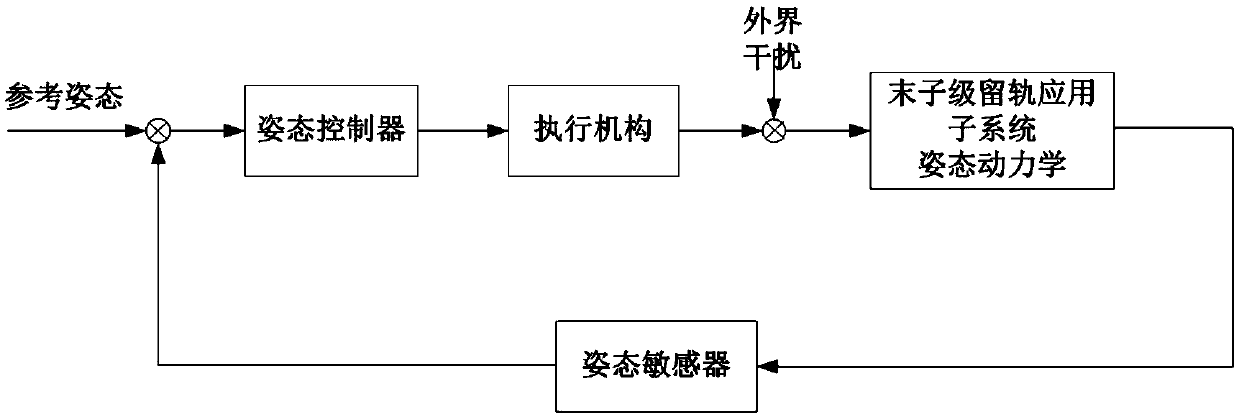
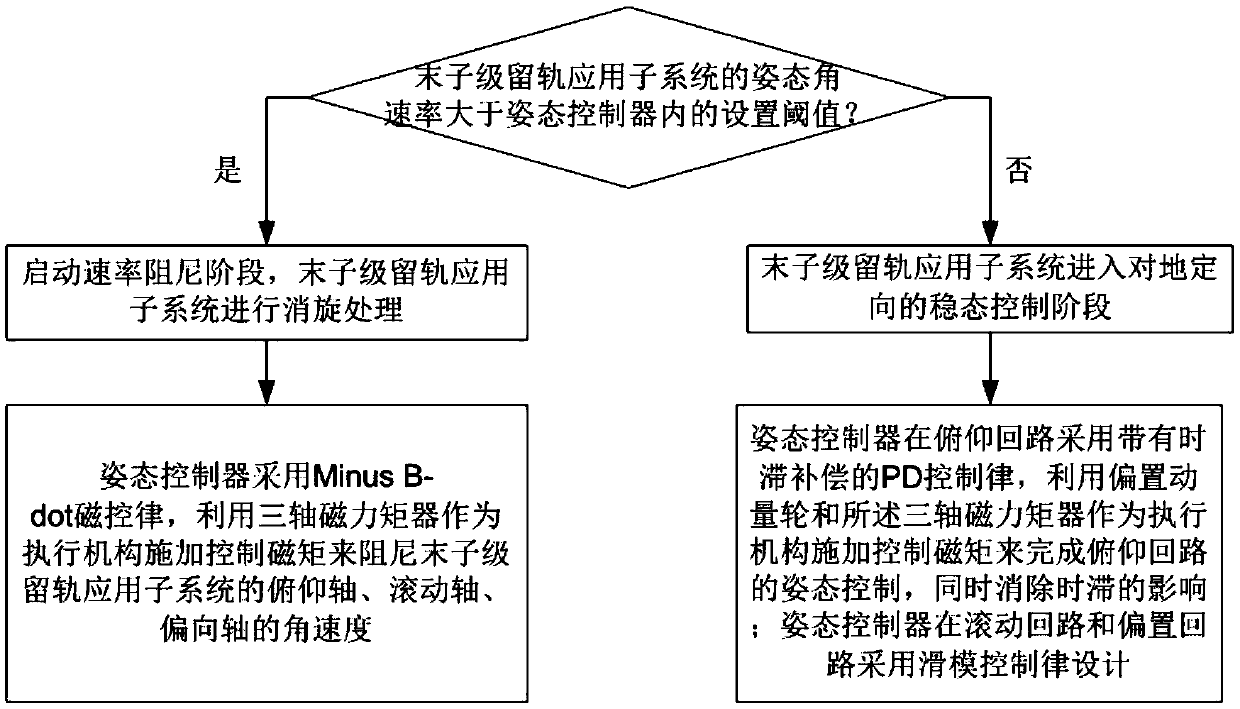
The invention discloses a last stage orbit remaining application subsystem attitude control method. The method includes the steps that when a last stage orbit remaining application subsystem is in a rate damping period, an attitude controller adopts a Minus B-dot magnetic control law, a three-axis magnetic torquer is used as an execution mechanism for applying control magnetic torque, so that theangular speeds of a pitching axis, a rolling axis and a deviation axis of the last stage orbit remaining application subsystem are damped, and the last stage orbit remaining application subsystem is racemized; and when the last stage orbit remaining application subsystem is in a steady state control period, the attitude controller adopts a PD control law with time-lag compensation on a pitching loop, a bias momentum wheel and the three-axis magnetic torquer are used as execution mechanisms for applying the control magnetic torque, so that attitude control of the pitching loop is finished, anda rolling / yawing loop adopts sliding mode controller design. The sun pointing problem of the last stage orbit remaining application subsystem is solved, meanwhile, time-lag influence is eliminated, and the attitude control accuracy of the last stage orbit remaining application subsystem is improved.
Owner:SHANGHAI ASES SPACEFLIGHT TECH LTD CO
Automatic attitude control method and system for vertical take-off and landing unmanned aerial vehicle
PendingCN119024876Aimprove accuracyImprove robustnessVehicle position/course/altitude controlPosition/direction controlAutomatic controlGyroscope
The invention belongs to the technical field of unmanned aerial vehicle attitude automatic control, and discloses a vertical take-off and landing unmanned aerial vehicle attitude automatic control method, which comprises the following steps of: collecting angular velocity and acceleration data of an unmanned aerial vehicle by using a gyroscope and an accelerometer through a data acquisition module; and the main control module performs wireless communication control by using a wireless network through the wireless communication module. Positioning information and course control of the unmanned aerial vehicle are provided through the navigation module; performing data fusion on the INS and other sensor systems to form a combined navigation system; the sensor error in the IMU is modeled, so that compensation can be performed in the algorithm, and the navigation precision is improved; meanwhile, the system state is monitored through the fault detection module, and potential faults are diagnosed; the safety of the system is improved, and accidents are reduced; and the accuracy and robustness of unmanned aerial vehicle fault detection are improved.

Owner:SICHUAN DIGITAL ECONOMY IND DEV RES INST
Attitude health management method for helicopters based on hierarchical structure
ActiveCN110162074AImprove attitude control accuracyAchieve consistencyAttitude controlControl objectiveAttitude control
The invention discloses an attitude health management method for helicopters based on a hierarchical structure. The hierarchical structure for attitude health management of the helicopters comprises an attitude model and fault model layer of the helicopters, a fault detection layer, a health consistency layer, a fault-tolerant consistency layer and a virtual connection layer. A triggering mechanism for threshold setting of the fault detection layer determines the selection of a control law of the helicopters. If a health channel of the fault detection layer is triggered, the health consistencycontrol layer is accessed; and if a fault-tolerant channel of the fault detection layer is triggered, the fault-tolerant consistency control layer is accessed. Finally, health management and global consistency control objective are realized in the virtual connection layer. The method has the advantages that the structure is simple, the implementation logic is clear, the effect is obvious, the novel attitude health management method for the helicopters is provided, and the attitude control precision is improved, the health management is realized, a system for the helicopters has robustness andfault tolerance, and the reliability and the safety of the helicopters are further ensured.


Owner:NANJING UNIV OF AERONAUTICS & ASTRONAUTICS
Rocket last-stage attitude time-sharing control method and device based on fuzzy membership function
PendingCN114442647AGuaranteed reliabilityAddress reliabilityAttitude controlJet flowFuzzy control system
The invention relates to a rocket last-stage attitude time-sharing control method based on a fuzzy membership function, a fuzzy logic strategy is introduced into a last-stage rocket body attitude control system of a simplified side jet flow device, and the side jet flow device comprises a plurality of axial and radial jet pipes arranged on the outer side wall of the circumference of a cylindrical rocket body. The jet pipes jet airflow to provide pitching, yawing and rolling control moments for the rocket body, the final-stage attitude of the rocket is controlled according to the control characteristic quantity, different control jet pipe combinations are reasonably selected by using fuzzy logic rules, and a control strategy is executed. The core of the method is fuzzy logic design, a fuzzy control stylization method is utilized, the characteristic control quantity attitude angle and the attitude angular rate obtained through calculation of an inertial measurement unit are used as input, a fuzzy strategy is generated, then a corresponding control spray pipe is selected to act to apply control torque to a rocket body, and the attitude angle and the angular rate of the rocket body are changed. And the rocket body attitude meets the design requirements.


Owner:AEROSPACE SCI & IND KET TECH CO LTD
Gradually varied inertia liquid filling execution mechanism and method for controlling high-accuracy attitude of spacecraft
ActiveCN105204513ASmooth attitude parameter change curveImprove convergence accuracyAttitude controlAttitude controlFlywheel
The invention relates to a gradually varied inertia liquid filling execution mechanism and a method for controlling a high-accuracy attitude of a spacecraft. The gradually varied inertia liquid filling execution mechanism comprises a vacuum container (1) for fixing and installing a whole flywheel structure, a flywheel bearing (2), a flywheel motor (3) and a flywheel. The control method comprises the steps that a laminar flow boundary layer equation is established, velocity distribution in a boundary layer is calculated, and an attitude kinetic equation of the spacecraft in the inertia changing process of the execution mechanism is established to obtain control toque Tc required by attitude change and provided by the execution mechanism. By the adoption of the gradually varied inertia liquid filling execution mechanism and the method for controlling the high-accuracy attitude of the spacecraft, the executing capacity of the attitude control execution mechanism is improved in the attitude control process, the output torque coverage range is widened, and meanwhile the problems of dynamic unbalance, too large resistance and the like brought by structure and process design problems during high-frequency rotation of a rotation part are decreased.
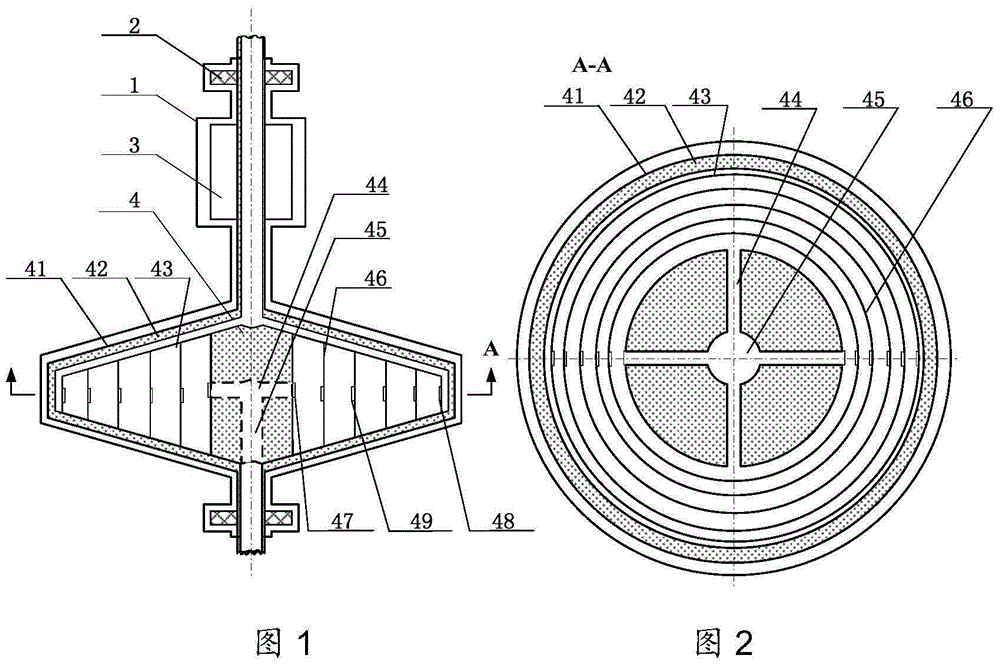
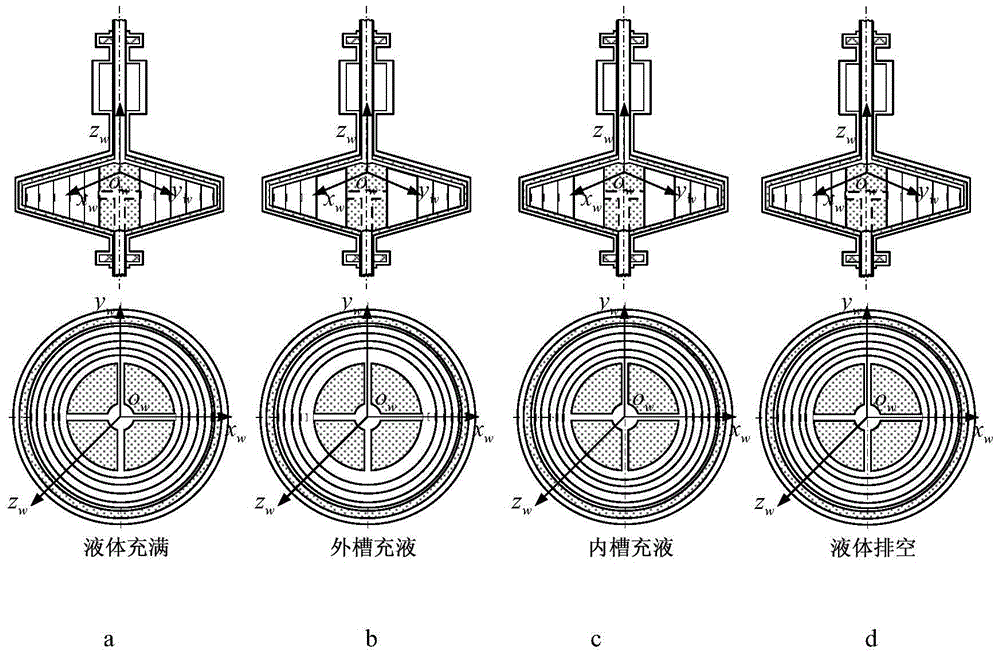
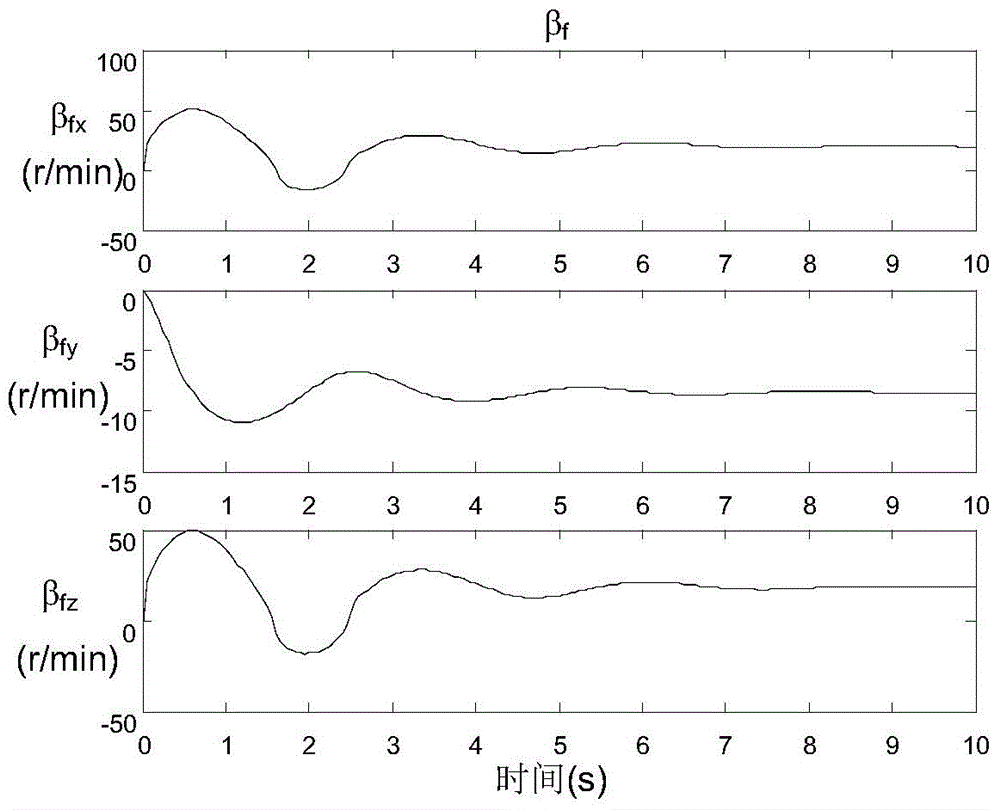
Owner:BEIJING INST OF CONTROL ENG
Gesture detection method and auxiliary device
ActiveCN103884322AImprove attitude control accuracyImprove test efficiency and test accuracySurveying instrumentsNavigation instrumentsAttitude controlComputer science


Owner:BEIJING RES INST OF MECHANICAL & ELECTRICAL TECH
Spraying robot and spraying method
ActiveCN111451057BLong blanking timeReduce weightAircraft componentsSpraying apparatusControl signalStructural engineering
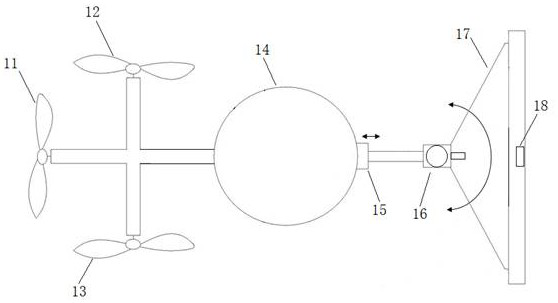
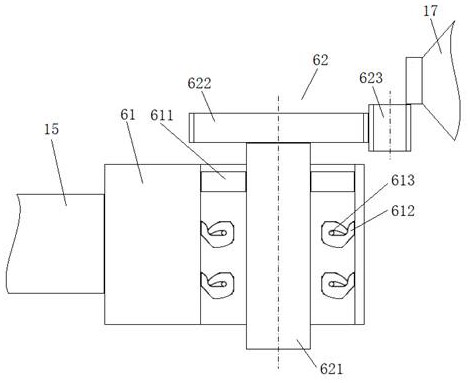
Owner:BEIJING HUALANDE TECH CONSULTING SERVICE CO LTD
Fault-tolerant control method of cube star sensor
InactiveCN107515613AImprove reliabilityImprove attitude control accuracyCosmonautic vehiclesCosmonautic partsDependabilityEmbedded system
The invention discloses a fault-tolerant control method for a cube star sensor. The method includes steps that the sensor starts reading and performs mean value verification on read data after each reading process; if an M value is within a sensor normal reading range, the reading is correct and direct output is performed; if the M value is not within the sensor normal reading range, the reading of the last process is output and an error count Terror is added with 1; if the error count Terror is greater than 3, the sensor is switched and zero setting is performed on the error count Terror; if the error count Terror is not greater than 3, the sensor performs reading continually and the above steps are repeated. According to the invention, after the sensor breaks down, real time monitoring and automatic switching are performed, so that satellite attitude determining reliability is improved substantially.

Owner:NANJING UNIV OF SCI & TECH
Thrust control device and power system of orbital air vehicle and orbital air vehicle
ActiveCN119305757AImprove mobilityImprove attitude control accuracyCosmonautic propulsion system apparatusFlight vehicleThree-dimensional space
The invention discloses a thrust control device and a power system of an orbital vehicle and the orbital vehicle. The thrust control device comprises a supporting frame which comprises a first sub-supporting frame and a second sub-supporting frame, and the first sub-supporting frame and the second sub-supporting frame are installed on a base of the orbiter; and the thrust direction adjusting structure is installed on the first sub-supporting frame and the second sub-supporting frame, and the thrust direction adjusting structure adjusts the thrust direction of an engine of the orbital aircraft in a three-dimensional space. Therefore, the maneuverability of the aircraft is improved.

Owner:BEIJING INFINITE AEROSPACE TECHNOLOGY CO LTD
Glass cleaning robot and cleaning method
PendingCN111374587ALong blanking timeReduce weightAircraft componentsAutomatic obstacle detectionControl signalUncrewed vehicle
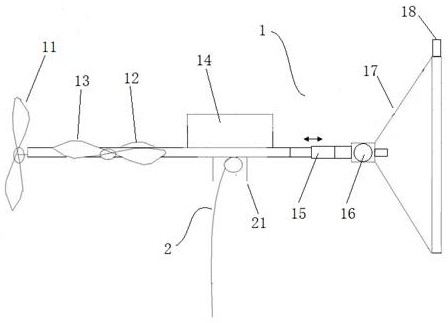
The invention discloses a glass cleaning robot and a cleaning method and belongs to the field of unmanned aerial vehicle control. The cleaning robot comprises an unmanned aerial vehicle, a mooring rope and a ground trolley; the unmanned aerial vehicle comprises a cleaning reaction force adjusting device, a telescopic long rod device, a steering device and the like; the telescopic long rod device comprises a telescopic adjustable long rod and is used for driving the cleaning device to move back and forth along with the telescopic adjustment of the long rod; the steering device comprises a fixing base and a rotating body and is used for driving the cleaning device to rotate leftwards and rightwards along with rotating adjustment of the rotating body; the cleaning reaction force adjusting device is connected with the other end of the telescopic long rod device and used for generating a pair of reaction forces acting on the unmanned aerial vehicle when the cleaning device sprays liquid; the mooring rope is used for conveying power supply power of the unmanned aerial vehicle, transmitting a control signal and conveying cleaning water and cleaning liquid for cleaning; the ground trolleyis used for generating the control signal and storing the cleaning liquid. The glass cleaning robot of the invention has the advantages of low power and wide application range.
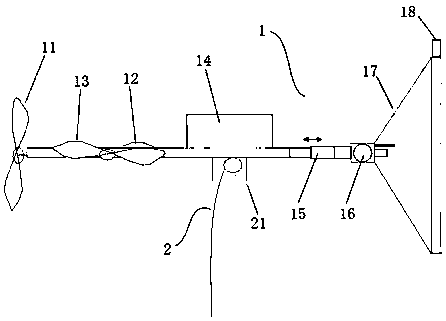
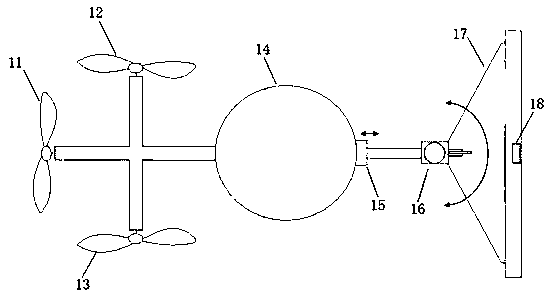
Owner:BEIJING HUALANDE TECH CONSULTING SERVICE CO LTD
Steering error compensation device, method and equipment for multi-hinge and multi-axle vehicle and medium
PendingCN119239754AImprove attitude control accuracyreduce wearSteering linkagesAutomatic steering controlAttitude controlControl engineering
The invention relates to the field of multi-hinged vehicles, and provides a steering error compensation device, method and equipment for a multi-hinged and multi-axle vehicle and a medium, and the device comprises the steps that steering controllers are arranged on a vehicle head and a vehicle tail respectively; hinge assemblies are arranged between the vehicles. A steering execution assembly is connected to an axle of an axle of each vehicle through a longitudinal pull rod, and the steering execution assemblies are symmetrically arranged on the two sides in the vehicle. The steering angle of the vehicle is compensated through the steering inner wheel difference between the shafts of the vehicle, and the running posture of the whole vehicle is controlled. The road occupation risk of the vehicle is reduced, and the outline envelope width of vehicle driving is effectively reduced. The vehicle attitude control precision is improved, the connection relation between the vehicles is fully decoupled, the transverse stress of the wheels is smaller, the abrasion of the wheels is reduced, the tail amplification coefficient of the vehicle is reduced, and the riding comfort of passengers is improved. The flexibility of the vehicle can be improved, the vehicle can change directions and turn around conveniently, and the integration degree of the steering device is higher.

Owner:CRRC DALIAN CO LTD
A multi-axis maneuvering imaging satellite yaw attitude control method considering the ellipticity of the earth
ActiveCN103941740BImprove attitude control accuracyMeet the needs of useAttitude controlNatural satelliteEarth's rotation
According to a yaw attitude control method of a multi-axis maneuver imaging satellite with ellipticity of the earth considered, satellite rolling and attitude maneuver conducted in pitching are considered, misalignment of an optical axis of optical load and a collimation axis of the optical load are also considered, and the defect that a traditional control method can be adapted only to satellite side wing maneuver and the optical axis is aligned with the collimation axis is overcome. In the process of obtaining a linear speed of a ground target point relative to a satellite, the speed is divided into three parts of a linear speed caused by earth rotation, a satellite orbit operation speed and an operation speed of the ground target point relative to the satellite caused by satellite orbit angular velocity. In the solving process of the satellite optical axis pointing to a ground target point vector, the rotating ellipsoid feature of an actual earth model is considered, coordinate transformation is introduced, simpleness and convenience of the method are guaranteed, and obtaining of high precision drift angle attitude is achieved. The yaw attitude control method of the multi-axis maneuver imaging satellite with ellipticity of the earth considered is suitable for simultaneous maneuver of the multi-axis of the satellite, and meets the usage requirements of most high precision to-earth imaging satellites at present.


Owner:BEIJING INST OF CONTROL ENG
Thrust control device and power system of orbiter and orbiter
ActiveCN119305757BImprove mobilityImprove attitude control accuracyCosmonautic propulsion system apparatus
The present application discloses a thrust control device and a power system of an orbital vehicle and an orbital vehicle. The thrust control device comprises: a support frame, comprising a first sub-support frame and a second sub-support frame, wherein the first sub-support frame and the second sub-support frame are mounted on a base of the orbital vehicle; and a thrust direction adjustment structure, which is mounted on the first sub-support frame and the second sub-support frame, and the thrust direction adjustment structure adjusts the thrust direction of the engine of the orbital vehicle in three-dimensional space. Thereby, the maneuverability of the aircraft is improved.

Owner:BEIJING INFINITE AEROSPACE TECHNOLOGY CO LTD
A posture detection method and auxiliary device
ActiveCN103884322BImprove attitude control accuracyAccurate postureSurveying instrumentsNavigation instrumentsAttitude controlComputer science


Owner:BEIJING RES INST OF MECHANICAL & ELECTRICAL TECH
liquid damper
ActiveCN107191522BImprove attitude control accuracyEnhanced security designVibration dampersLiquid springsRelative displacementAttitude control
The invention discloses a liquid damper, which comprises a central shaft, a sleeve flange movably sleeved on the outside of the central shaft, and a corrugated tube. , the sealed chamber is provided with a damping fluid and a bladder whose volume is variable under the pressure of the damping fluid. When the liquid damper is used for vibration isolation, the disturbance generated by the disturbance source will cause relative displacement between the sleeve flange and the central axis, compress or stretch the bellows, and the damping fluid will flow due to the deformation of the sealing cavity. When the damping fluid flows, it will be pressurized and change its volume. The damping fluid and the capsule can cooperate to provide damping, consume energy, and play a role in suppressing vibration of the load, so that vibration can be better suppressed. For the vibration isolation performance of each frequency band Both are greatly improved, and provide effective guarantee for improving the attitude control accuracy of the spacecraft and strengthening the safety design of the spacecraft, and the structure is simple and easy to process.


Owner:CHANGCHUN INST OF OPTICS FINE MECHANICS & PHYSICS CHINESE ACAD OF SCI
A method of deflection satellite adaptive neural network sliding gesture control method
ActiveCN104898418BSuppress disturbanceAdapt to practical engineering applicationsAdaptive controlDynamic equationDynamic models
A flexible satellite adaptive neural network sliding mode attitude control method relates to a flexible satellite adaptive neural network sliding mode attitude control method. The invention is a flexible satellite adaptive neural network sliding mode attitude control method proposed to solve the problem of the attitude fluctuation of the flexible satellite due to the modal vibration of the sail board and the rotation of the antenna, and to reduce the stability of the system. In the method, the first step is to establish a flexible satellite attitude dynamics model; the second step is to obtain a simplified flexible satellite attitude dynamics equation; and the third step is to use the RBF neural network according to the simplified flexible satellite attitude dynamics equation. Design the sliding mode attitude controller; step 4, further use the RBF neural network to approximate the symbolic function η'sgn(s) to weaken the influence of chattering on the sliding mode attitude controller; obtain the sliding mode attitude controller after the chattering is weakened, etc. realized. The invention is applied to the field of flexible satellite attitude control.


Owner:HARBIN INST OF TECH
A method for measuring combined index system of satellite hemispherical resonator gyroscope
ActiveCN104034347BAvoid the influence of rotation angular velocityImprove calibration accuracyMeasurement devicesPerformance indexIndex system
The invention discloses an index system measurement method for a satellite hemispherical resonator gyro combination. The method comprises the steps of: utilizing a base level turning tooling to measure performance indexes of single gyro; using a triaxial rate turntable to measure the output data of the hemispherical resonator gyro combination; and calculating the setting angle deviation of gyros. The method provided by the invention can eliminate the influence of ground speed on calibrated error, avoids tedious calculation, solves the precision calibration problem of a satellite three-orthogonal one-oblique installed gyro combination, and improves the attitude control precision of an attitude control system.


Owner:SHANGHAI XINYUE METER FACTORY
A vehicle body posture detection method, system, terminal and storage medium
The application relates to the field of vehicle body posture detection, and specifically discloses a vehicle body posture detection method, a vehicle body posture detection system, a terminal and a storage medium, wherein infrared distance measuring sensors are installed at each wheel of a vehicle to measure the distance from the infrared distance measuring sensors to the ground; in response to the power-on of the vehicle, each infrared distance measuring sensor is triggered to operate, and a first measurement distance data is obtained; whether the first measurement distance data is normal is judged; if the first measurement distance data is normal, the first measurement is taken as the current basic posture data of the vehicle, and the current basic posture data is stored into historical data; if the first measurement distance data is not normal, the first measurement distance data is discarded, and the latest basic posture data in the historical data is selected as the current basic posture data of the vehicle. The application uses infrared distance measuring sensors to measure the vehicle body posture, and the measurement will not produce errors due to time elapse; meanwhile, the basic posture data is updated according to the measured distance data, the calculation deviation is corrected, and the control precision of the vehicle body posture is improved.

Owner:SINO TRUK JINAN POWER CO LTD
Posture correction method and computer device for controllable human image generation
ActiveCN118675233BImprove attitude control accuracyEasy to learnCharacter and pattern recognitionEngineeringAttention network
The present invention discloses a posture correction method and computer device for controllable human image generation, wherein the method comprises: S1: extracting a text feature tensor from a controllable human image generation model; S2: cropping and flattening the text feature tensor after pooling to obtain a one-dimensional text tensor; S3: adding the one-dimensional text tensor to the diffusion step tensor to obtain a conditional tensor; S4: slicing the predicted noise tensor to obtain a noise tensor; S5: adding the position number tensor to the noise tensor to obtain a new noise tensor; S6: inputting the new noise tensor into a layer normalization network and a multi-head self-attention network in sequence to obtain an output tensor; S7: inputting the output tensor and the conditional tensor into a multi-head cross-attention network at the same time to obtain a final predicted noise tensor; S8: generating a final image with higher posture control accuracy. The present invention can improve the accuracy of posture control.

Owner:NANJING UNIV OF POSTS & TELECOMM
A liquid-filled actuator with gradual inertia and a method for high-precision attitude control of spacecraft
ActiveCN105204513BSmooth attitude parameter change curveImprove convergence accuracyAttitude controlSpacecraft attitude controlActuator
The invention relates to a gradient inertia liquid-filled actuator and a method for high-precision attitude control of a spacecraft, wherein the gradient inertia liquid-filled actuator comprises: a vacuum container (1) for fixing and installing the entire flywheel structure, a flywheel bearing (2), Flywheel motor (3), flywheel (4); the control method is to establish a laminar boundary layer equation, calculate the velocity distribution in the boundary layer, establish the attitude dynamics equation of the spacecraft during the change of the inertia of the actuator, and obtain the attitude change The control torque Tc provided by the actuator is required. The invention improves the execution capability of the attitude control actuator during the attitude control process, increases the coverage range of the output torque, and simultaneously reduces the problems of dynamic unbalance and excessive resistance caused by the structure and process design problems when the rotating parts rotate at high frequency. .


Owner:BEIJING INST OF CONTROL ENG