

Patents
Literature
45results about How to "Improve sailing performance" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Articulated sailing watercraft
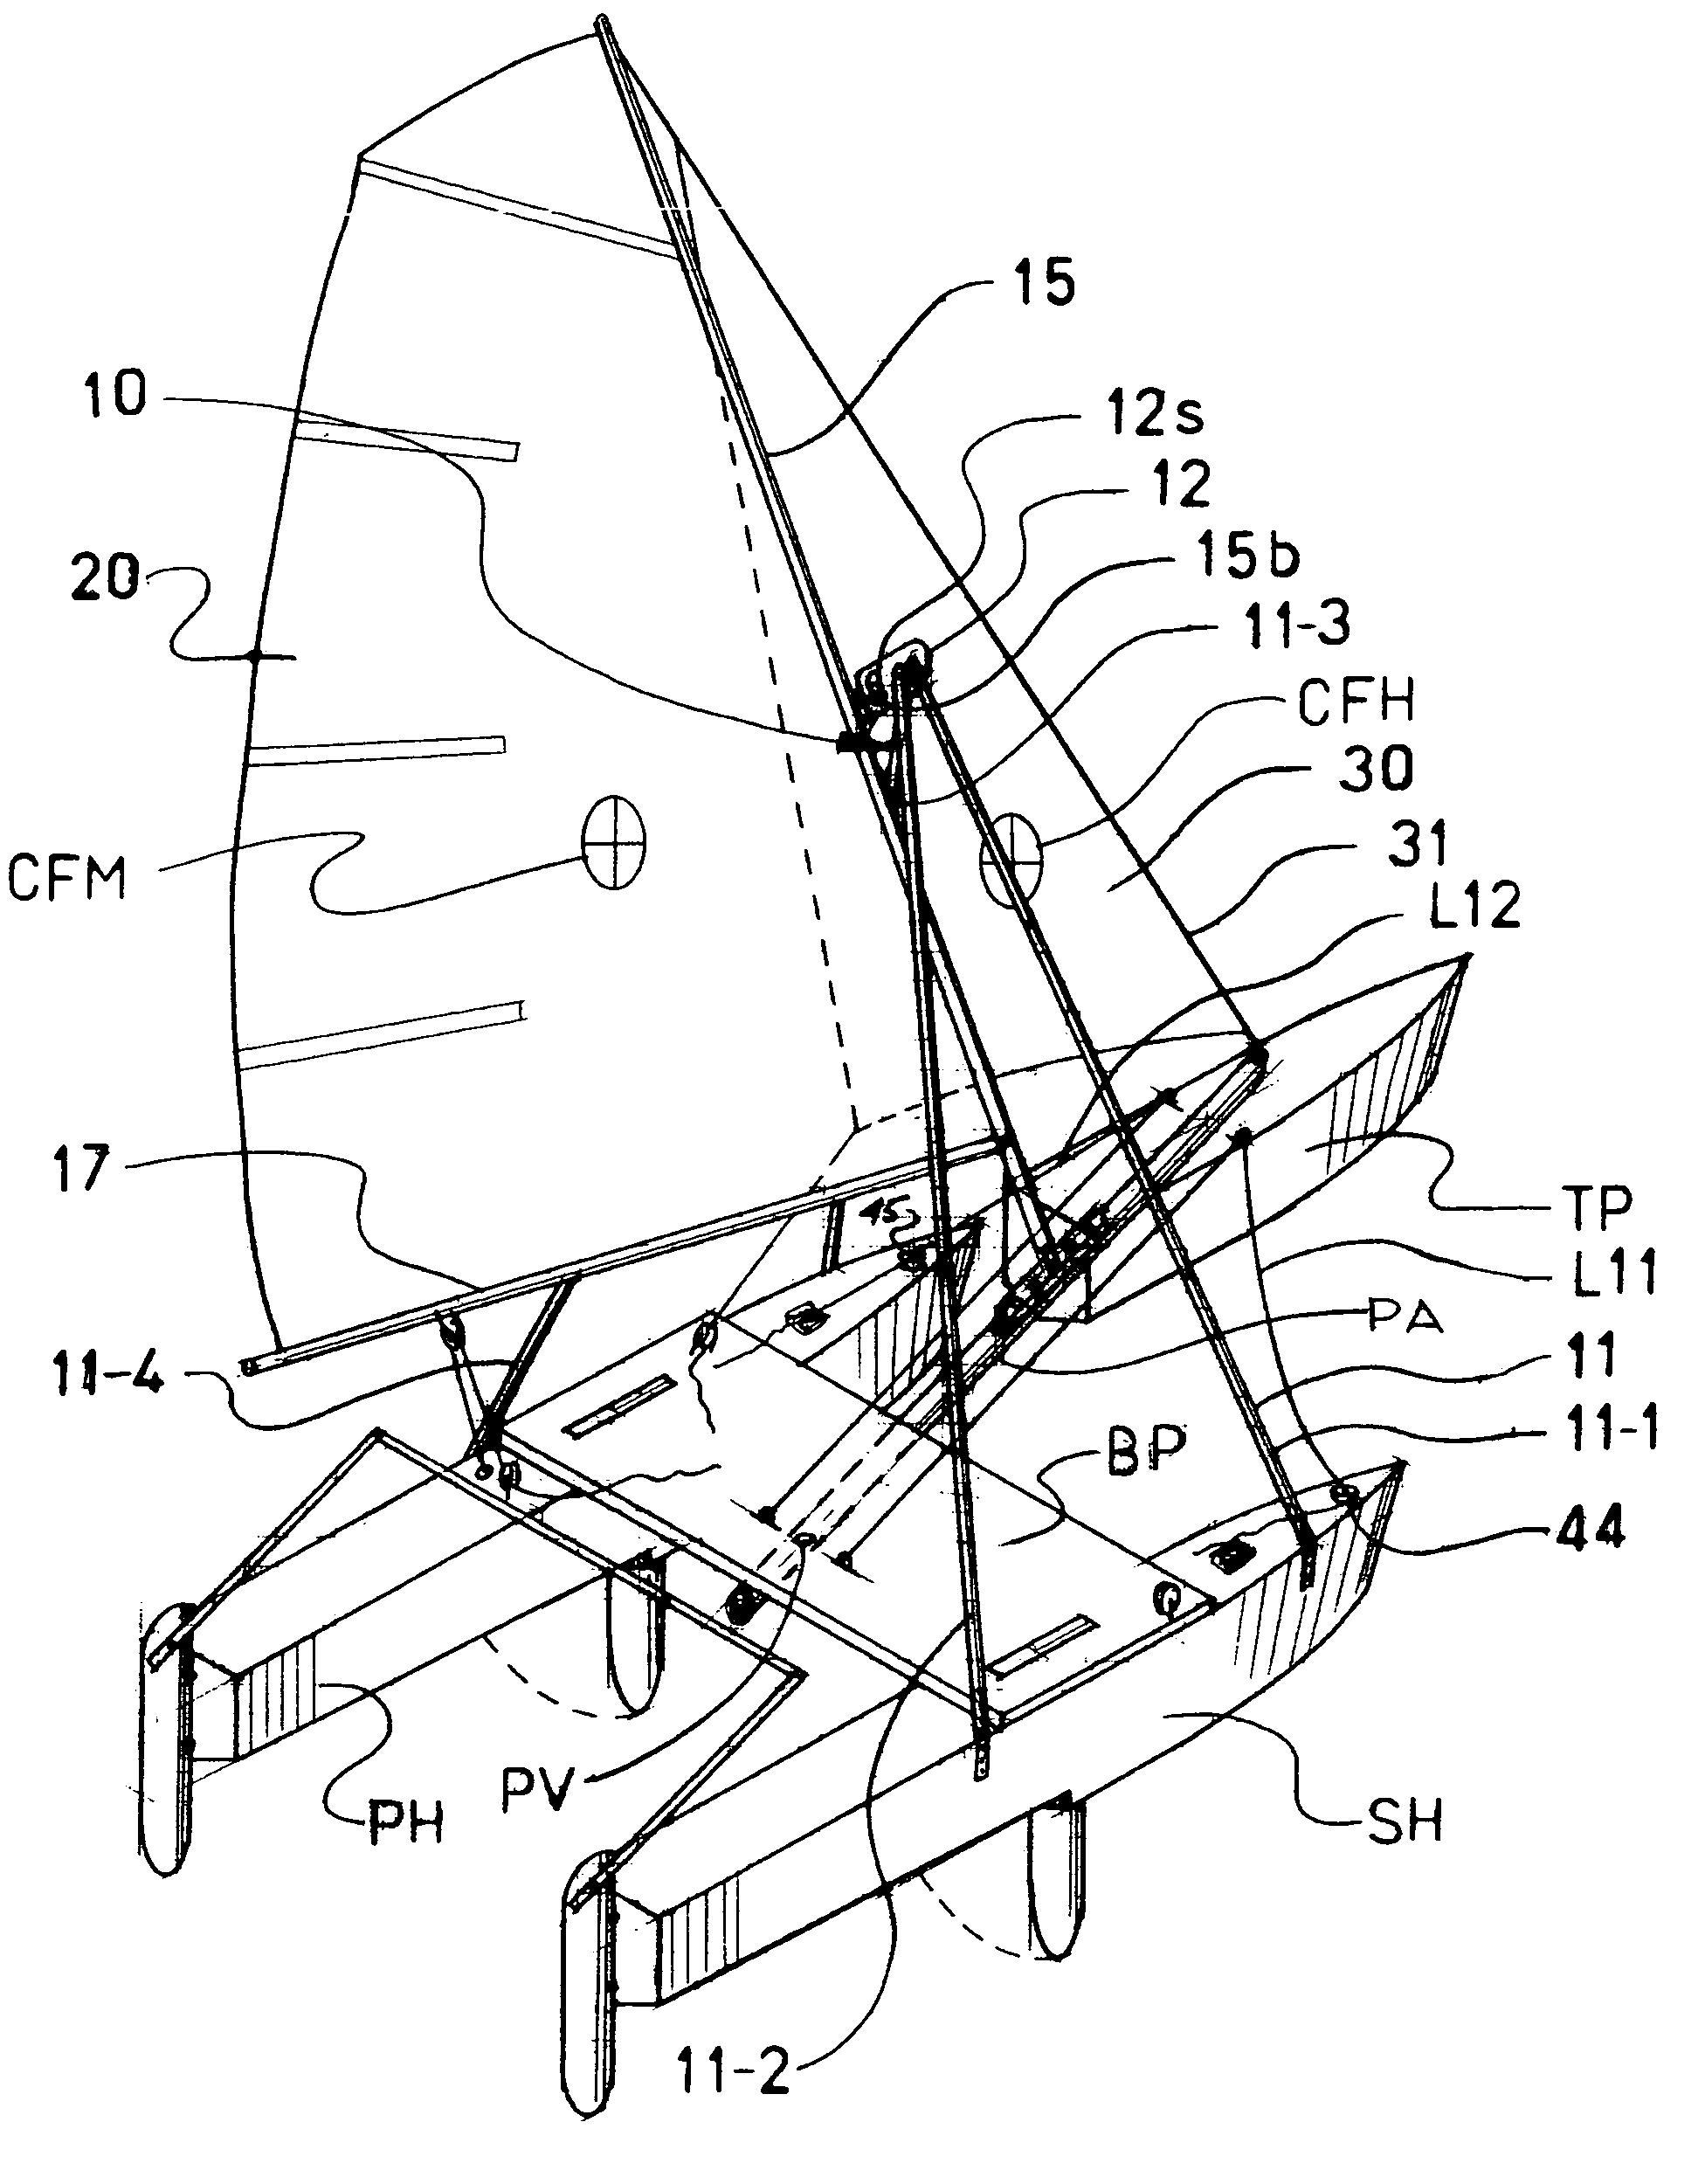
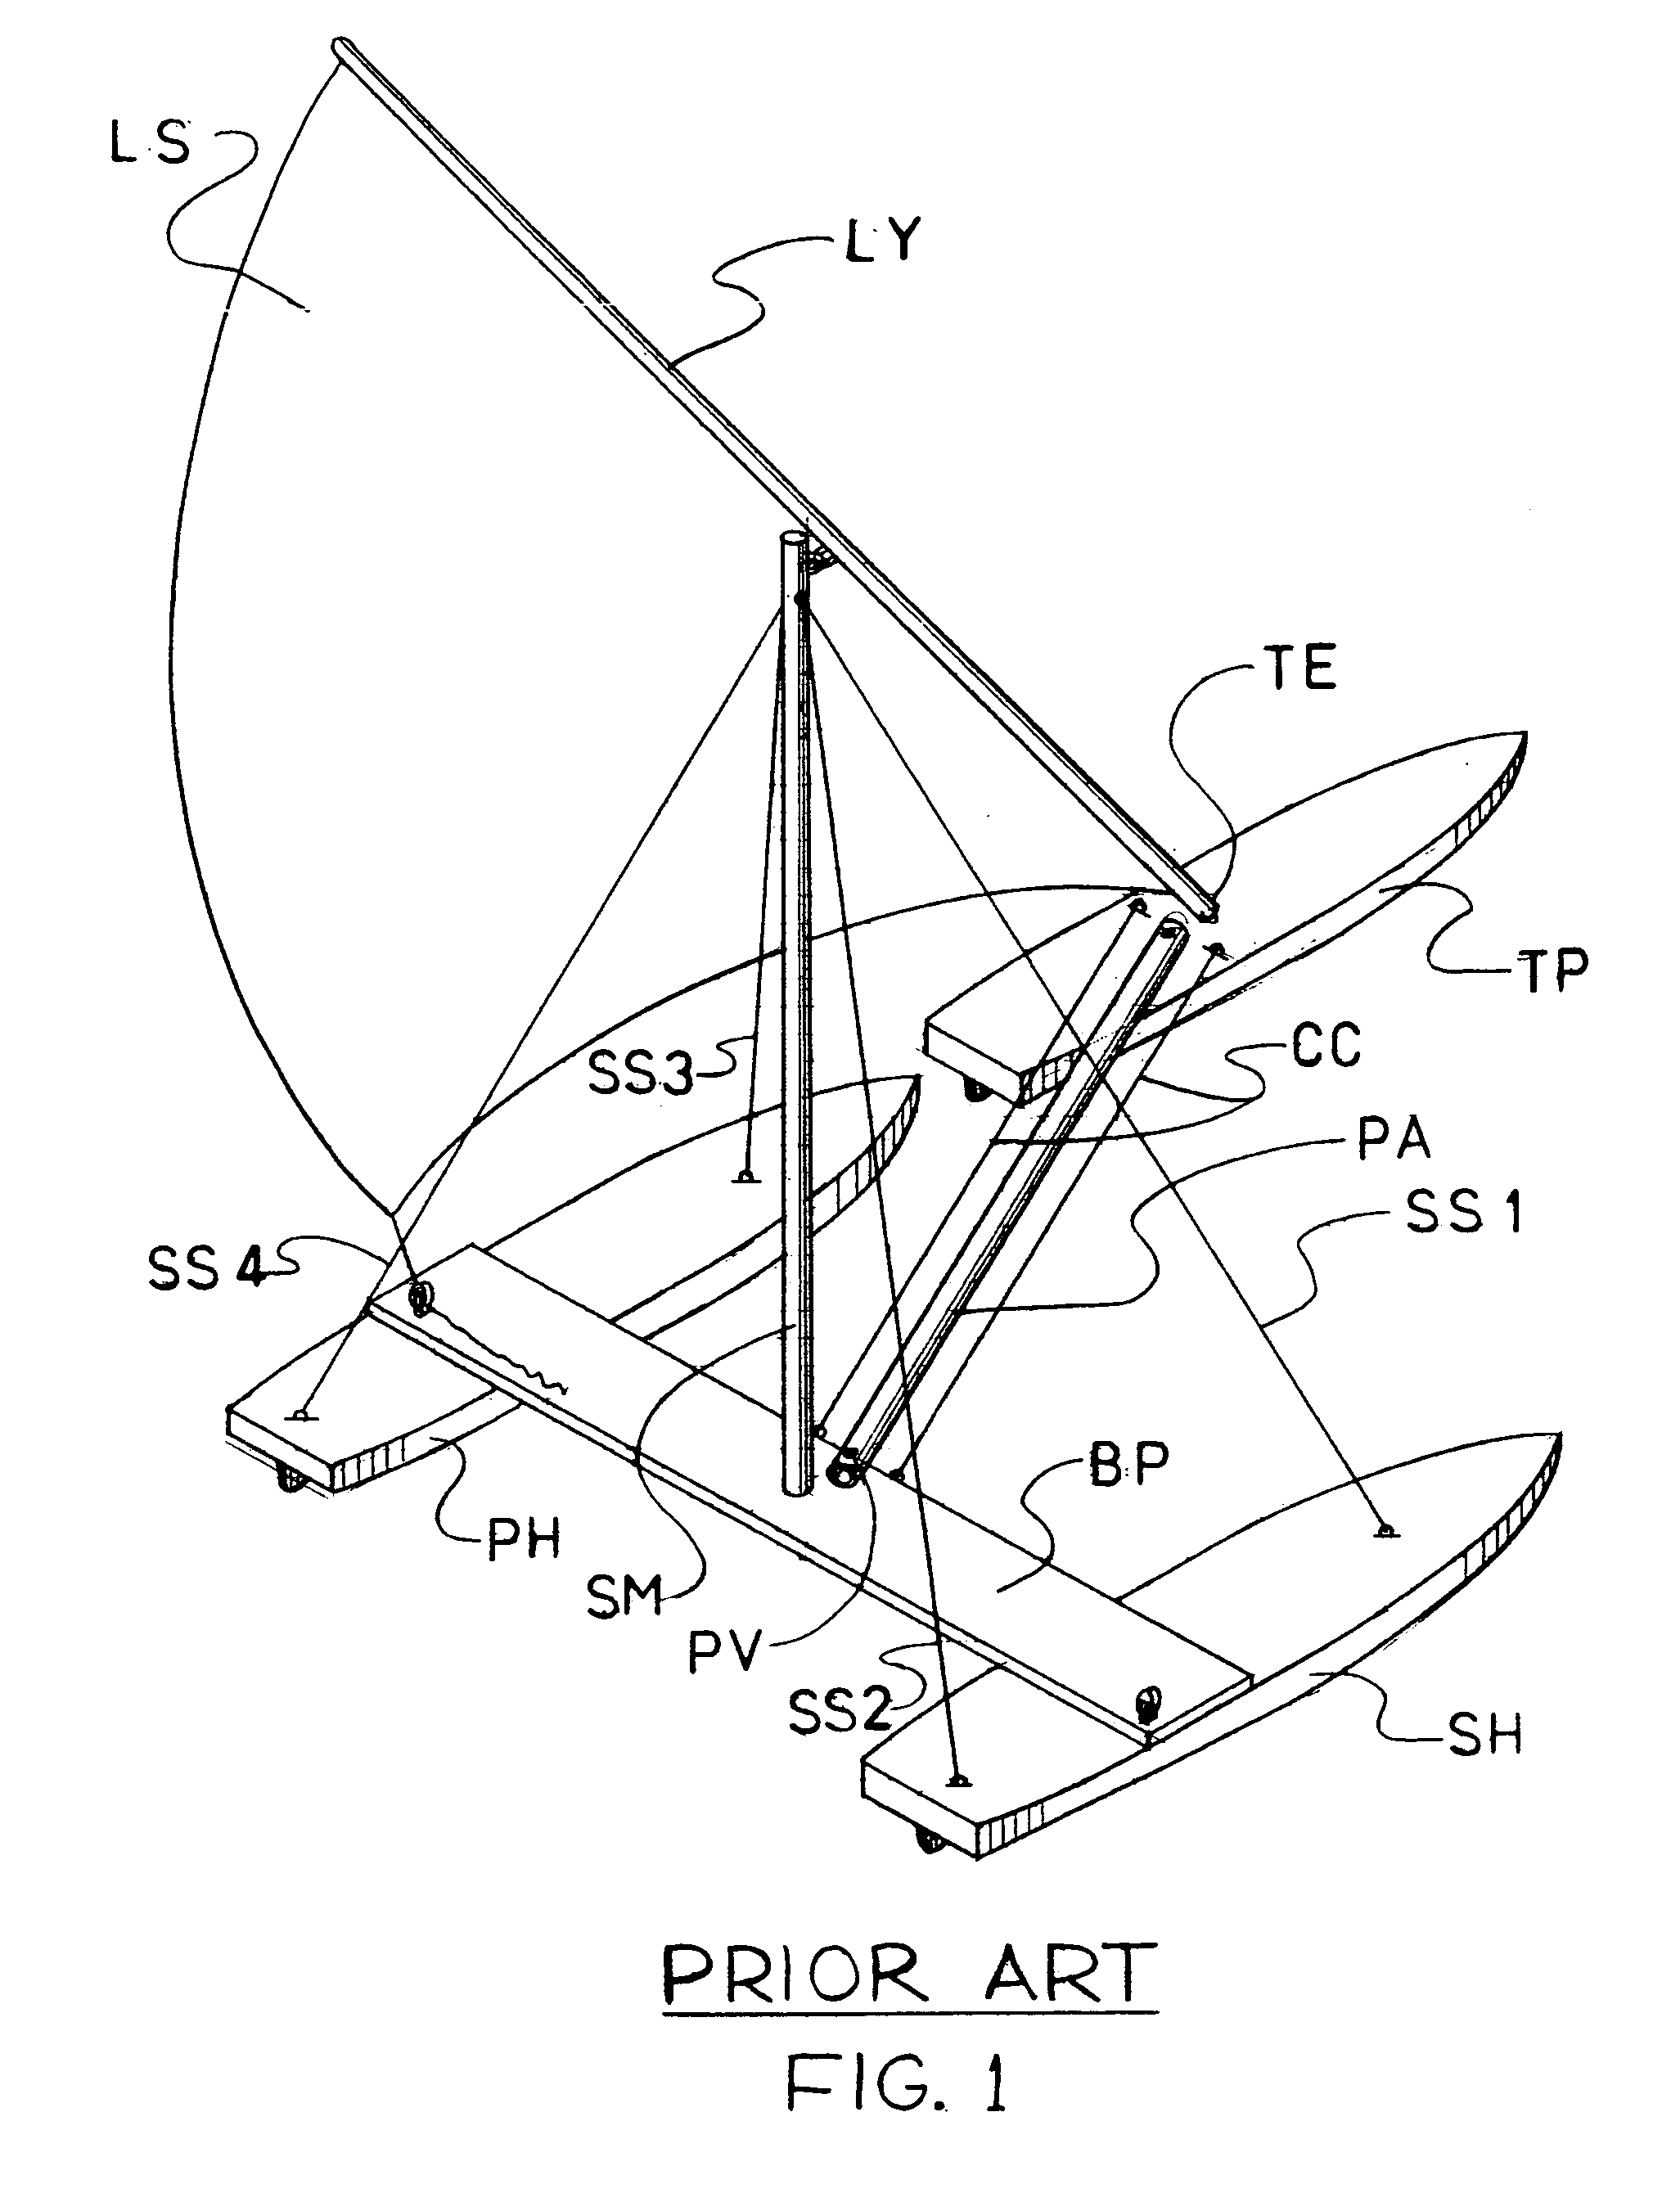
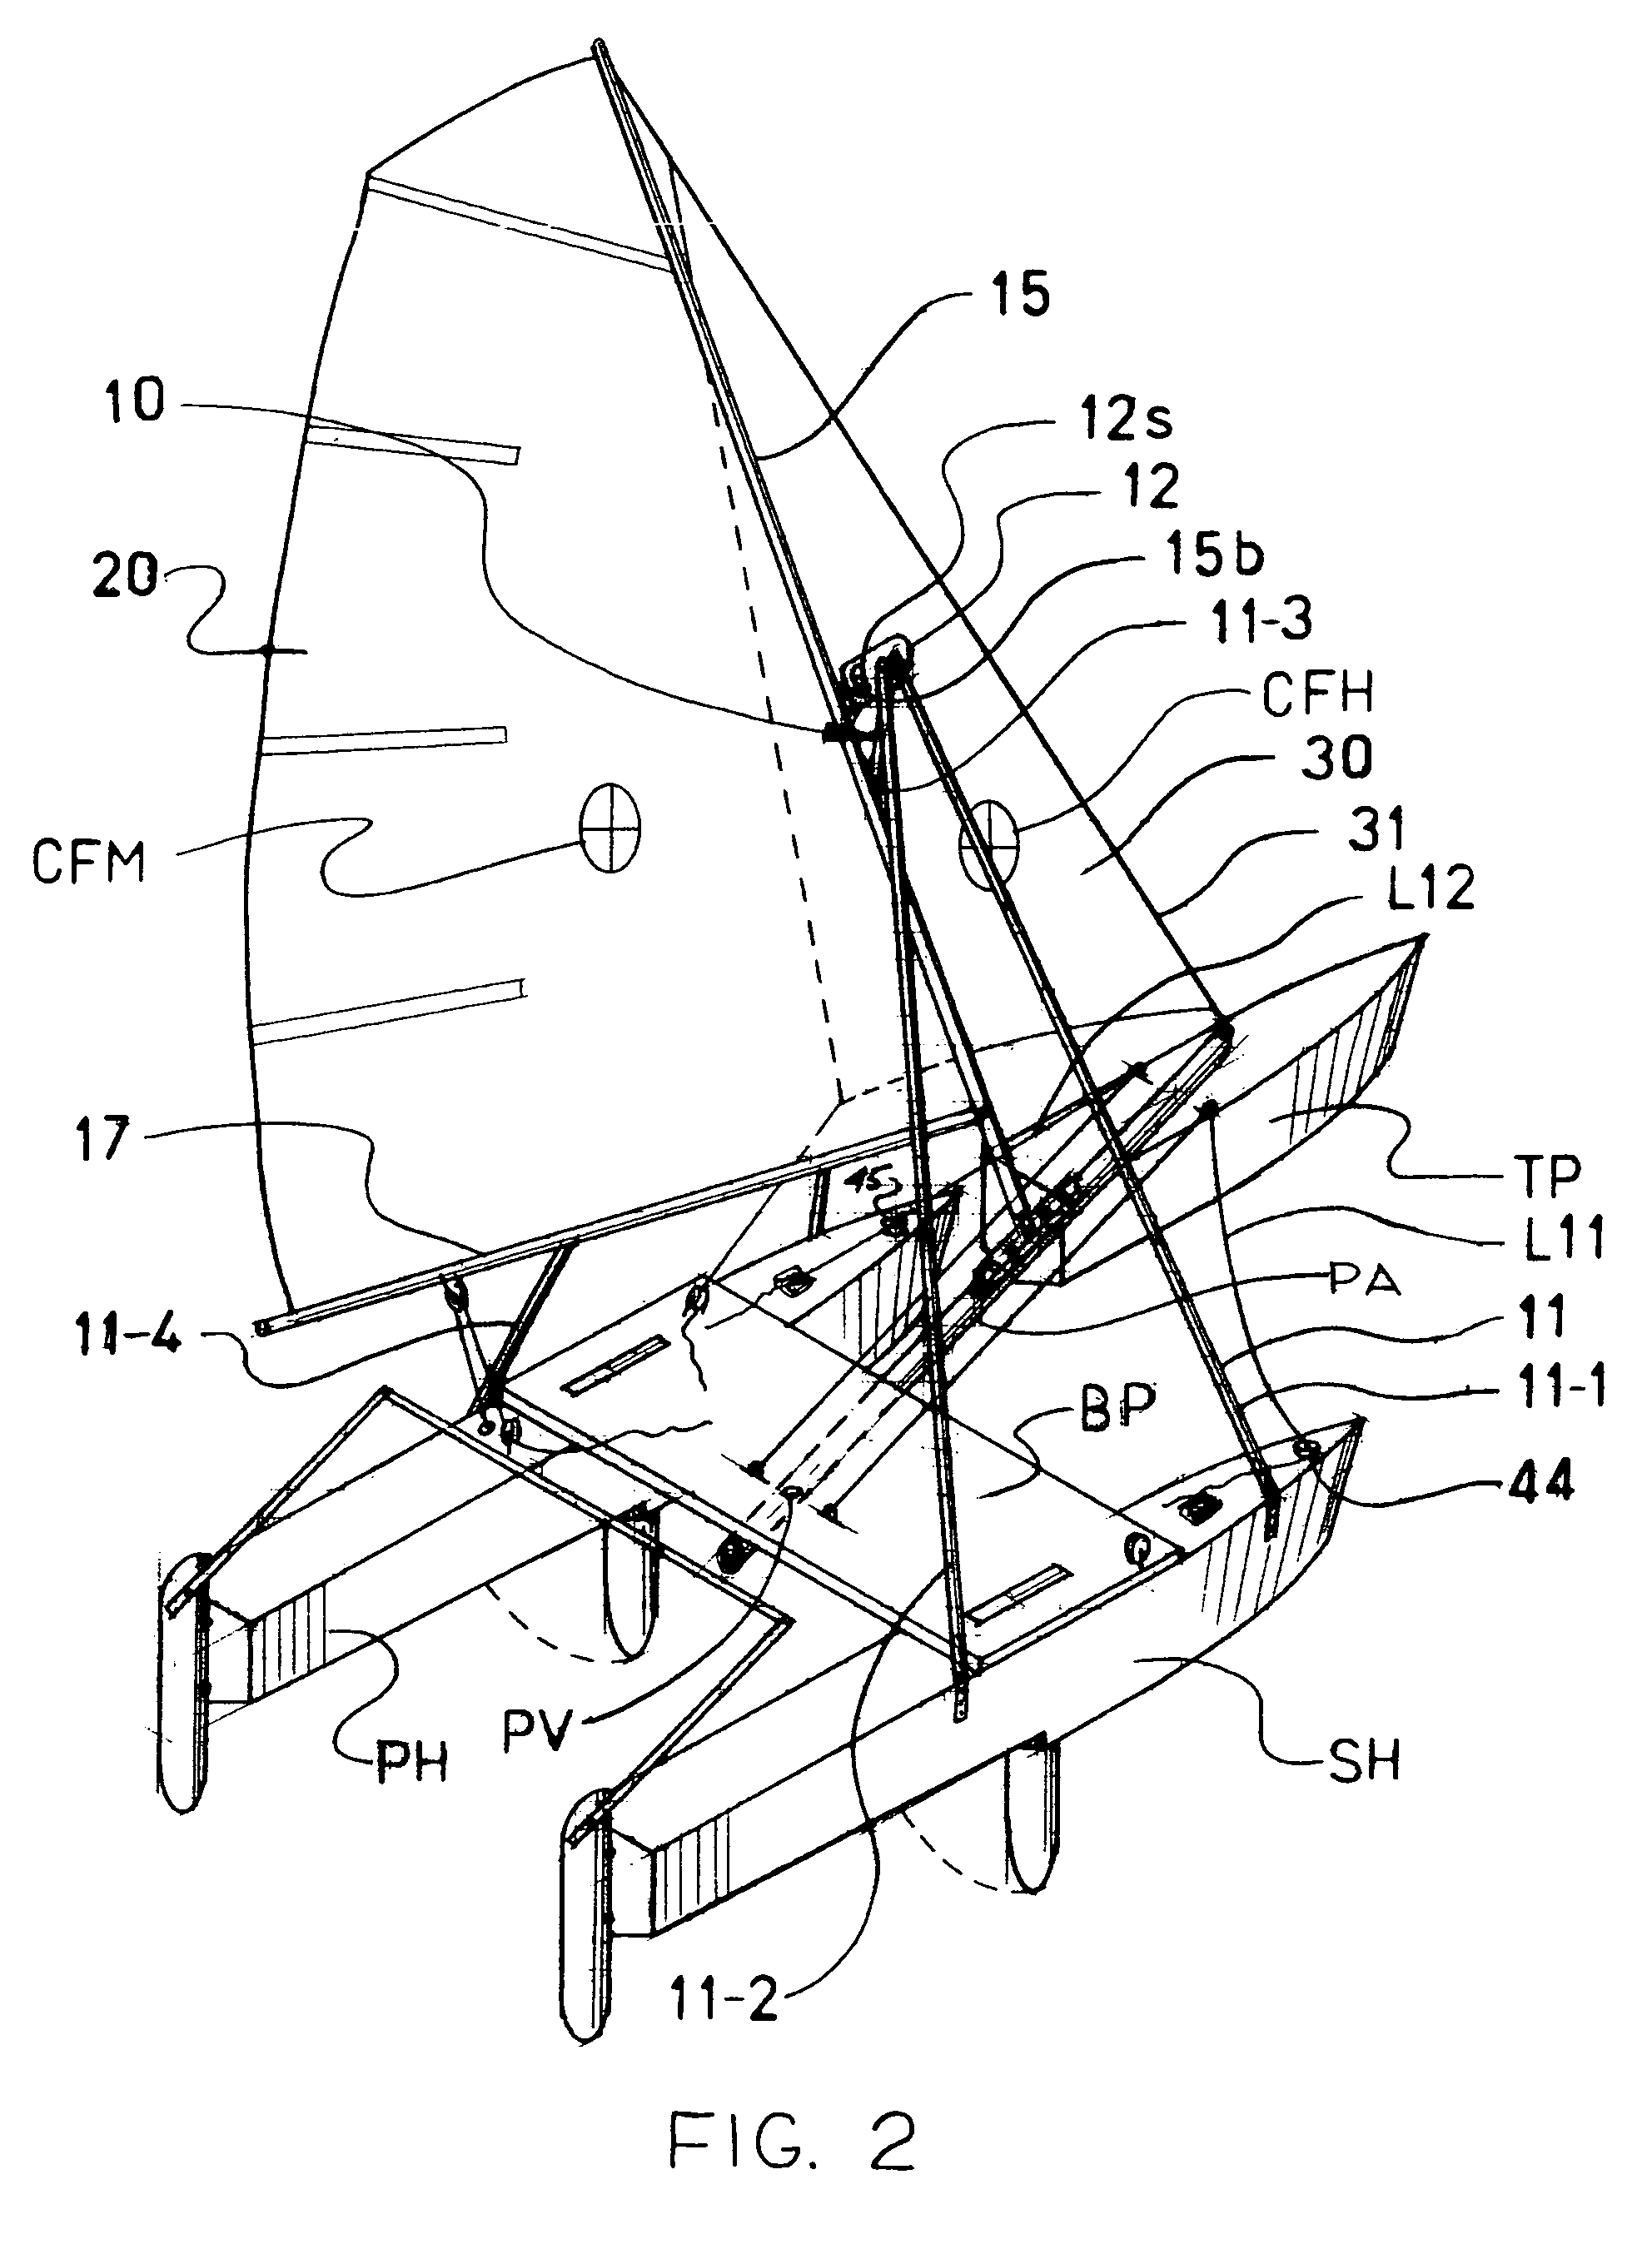
In a sailing catamaran provided with a forwardly directed pivoted arm carrying at the free end a third pontoon into alignment in front of either of the catamaran hulls a triangular truss assembly is provided bridging across the hulls. The apex of the truss assembly is then engaged to a point along the length of a mast which has its foot or base resting on the arm. A forestay stretched between the mast and the end of the arm supports a headsail while a mainsail is mounted on the mast.
Owner:BURRELL JAMES S
Tank stabilizer control device
ActiveCN101624087AImprove sailing performanceIncrease the effective cross-sectional areaVessel movement reduction by mass displacementEngineeringWater level
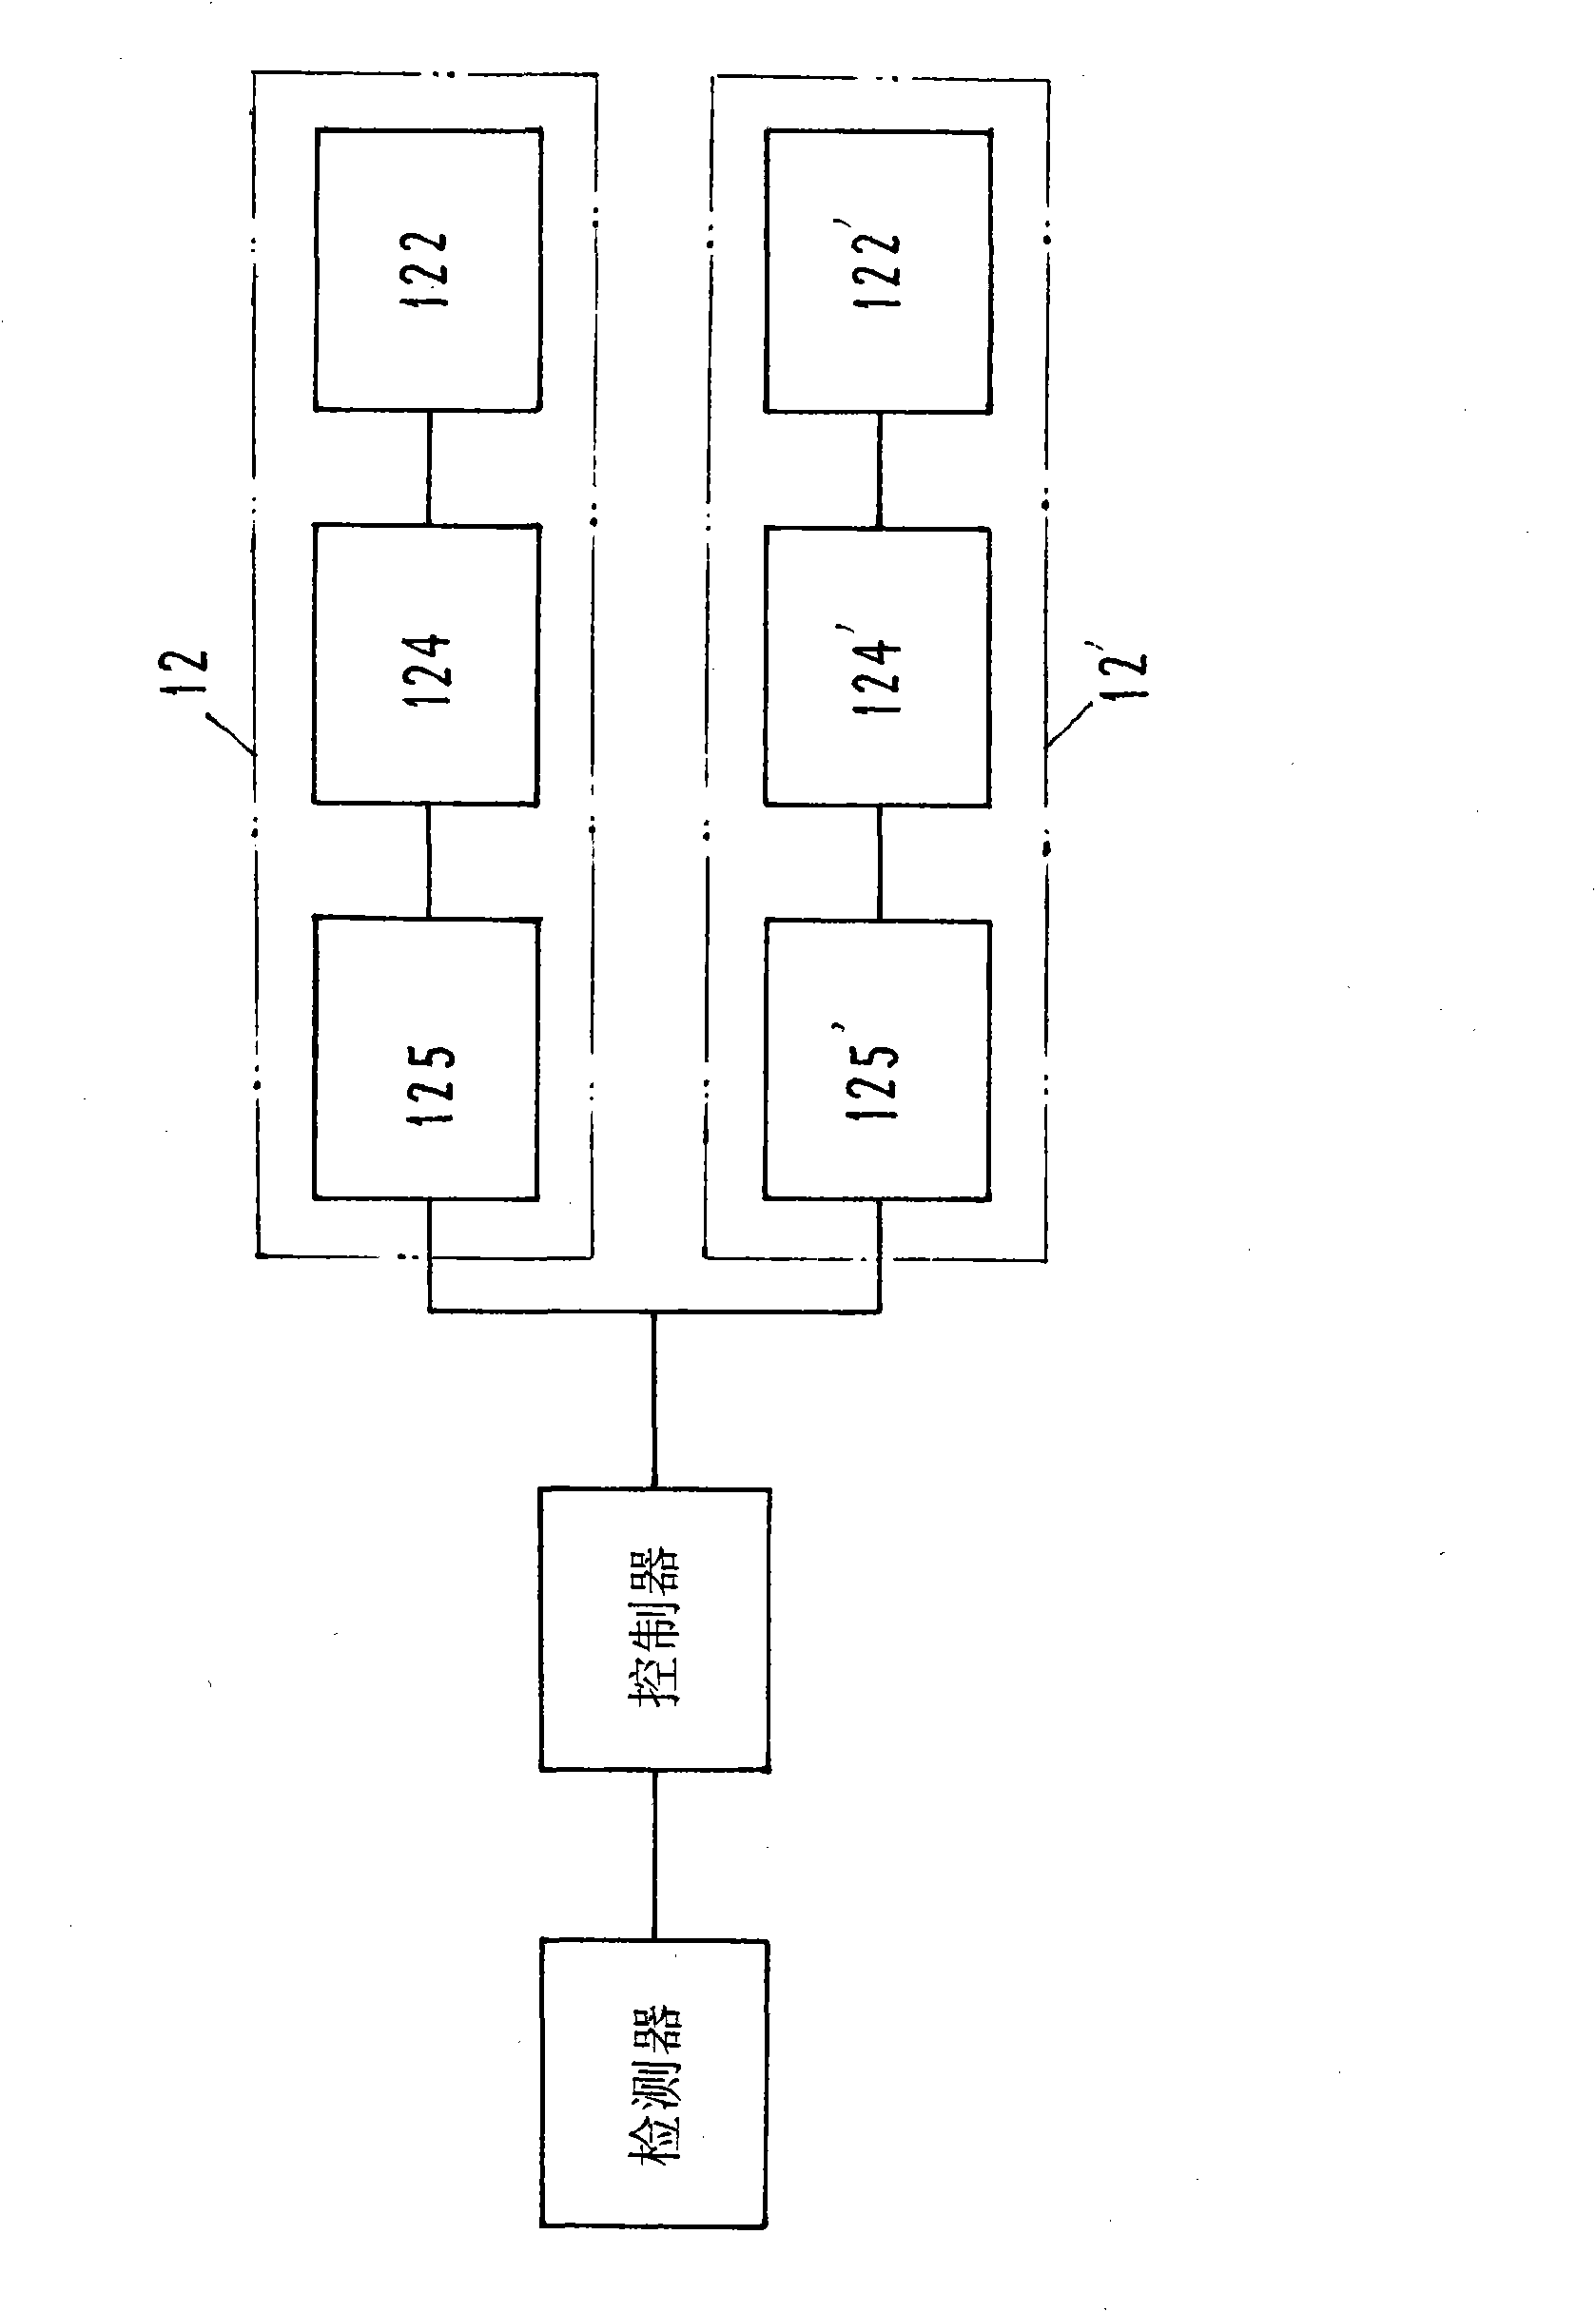
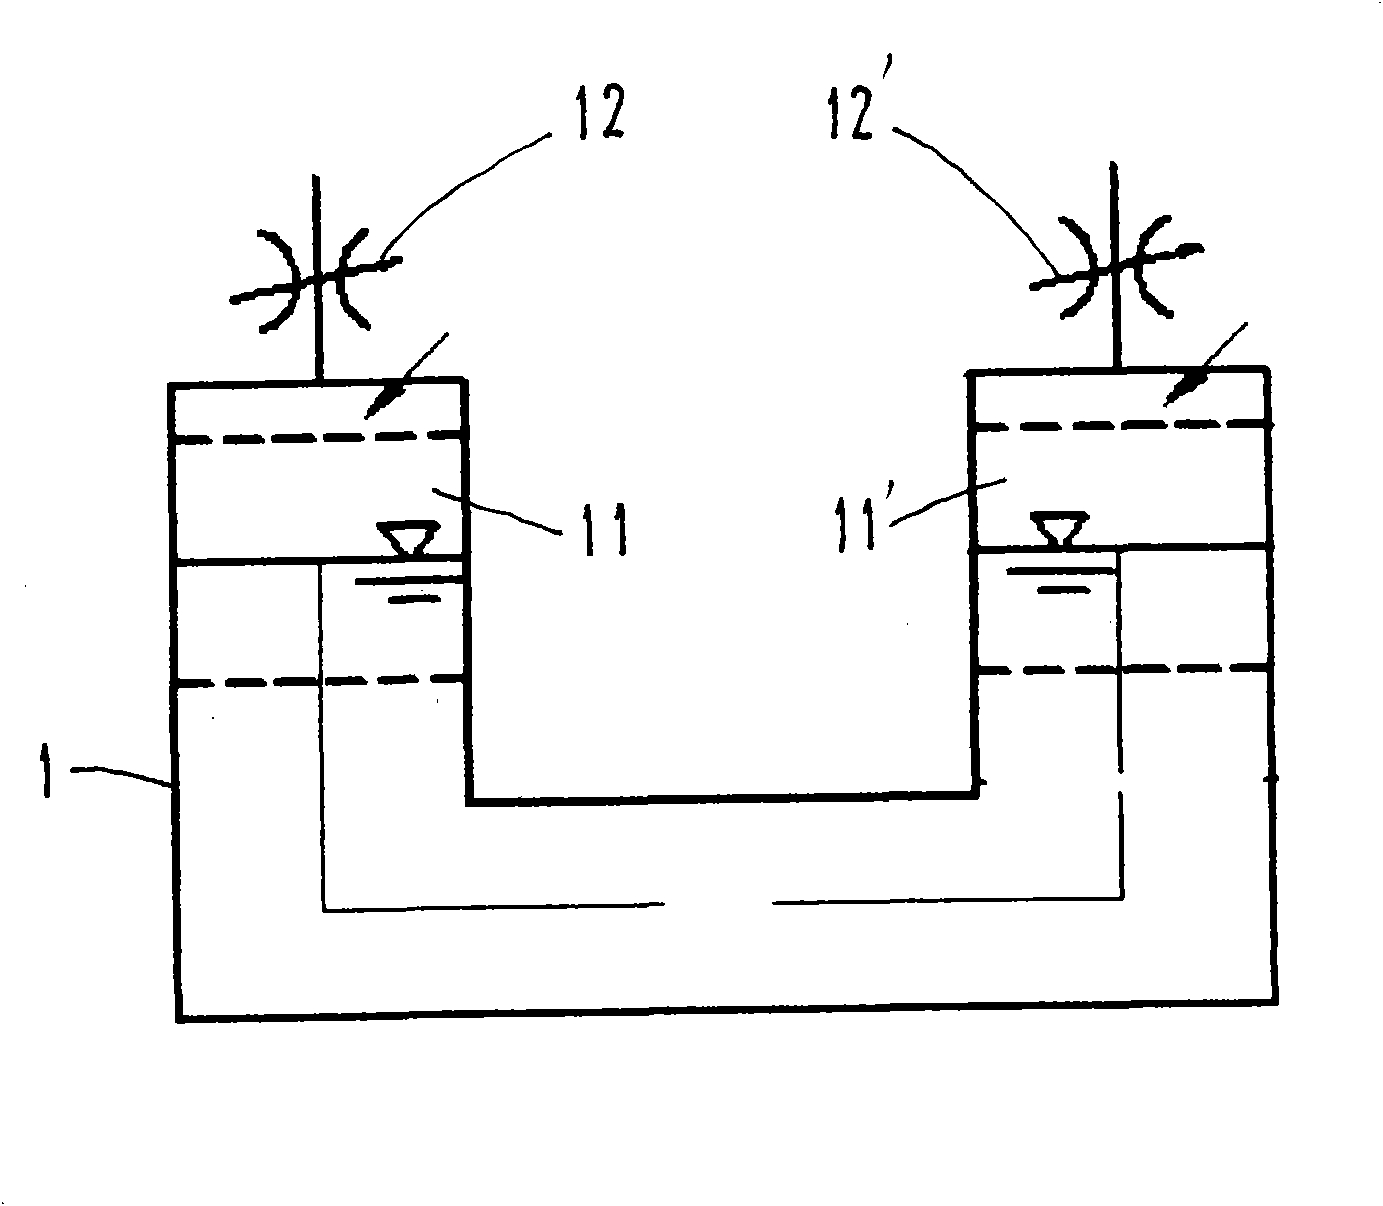
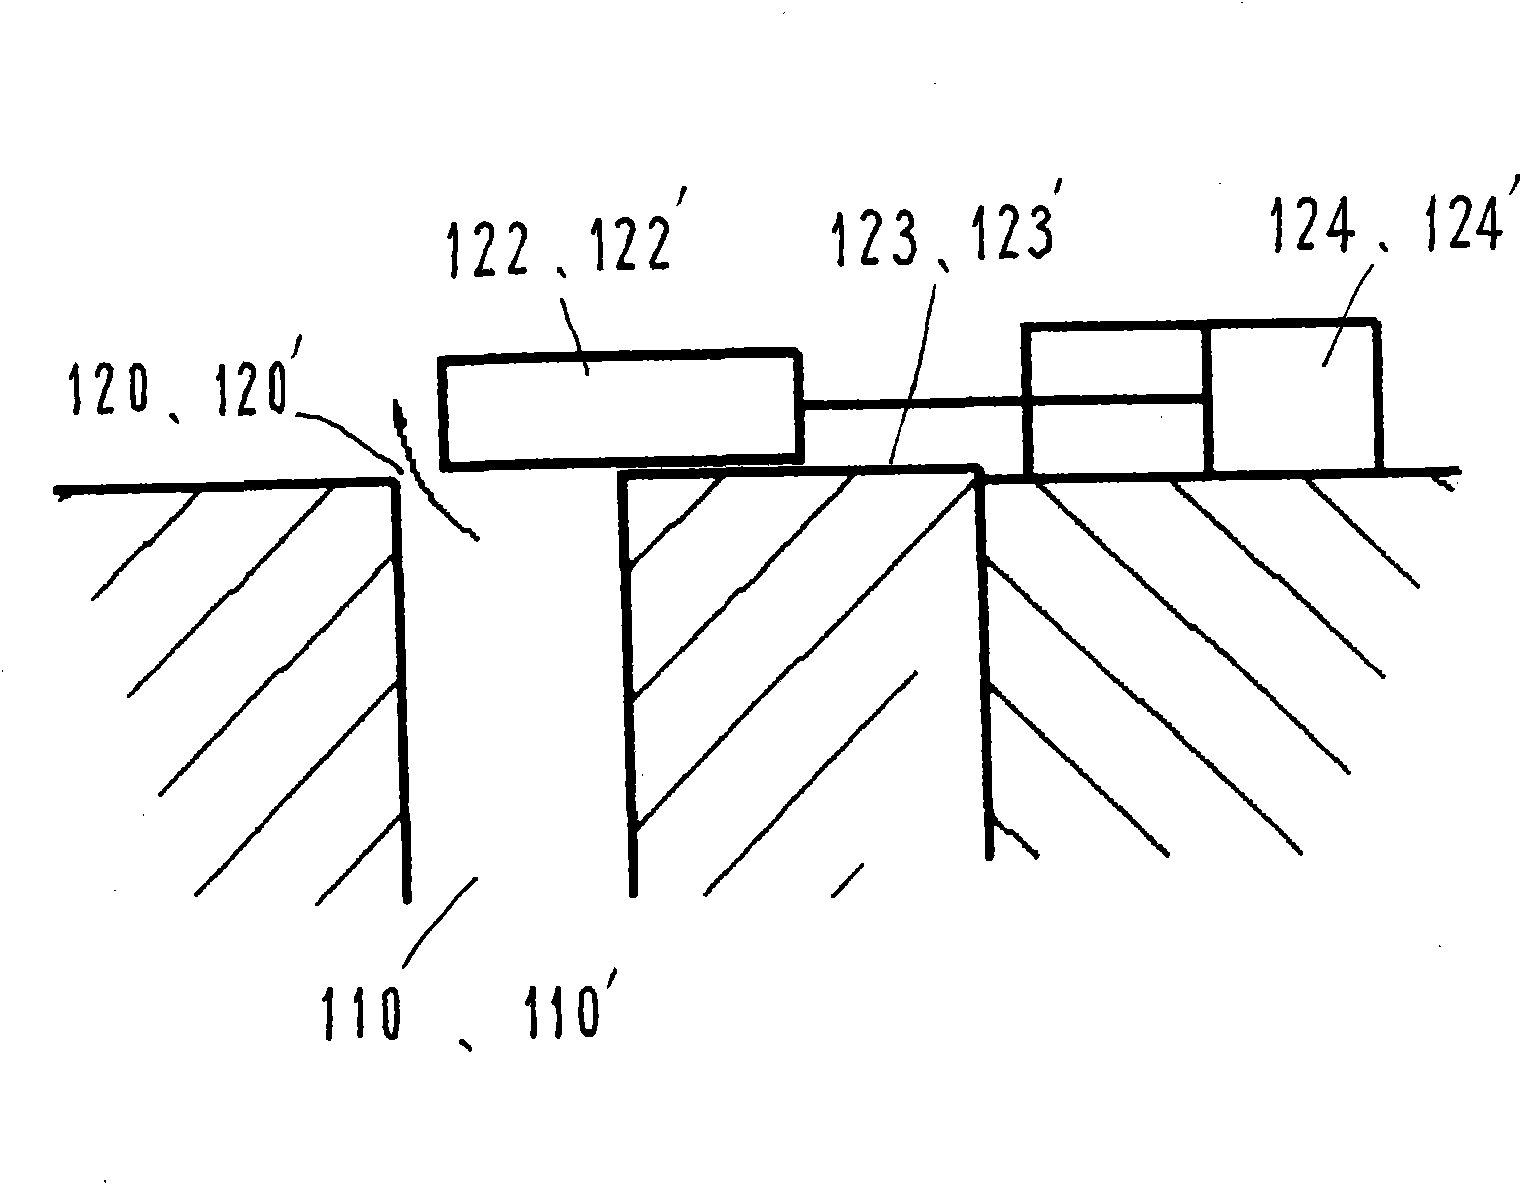
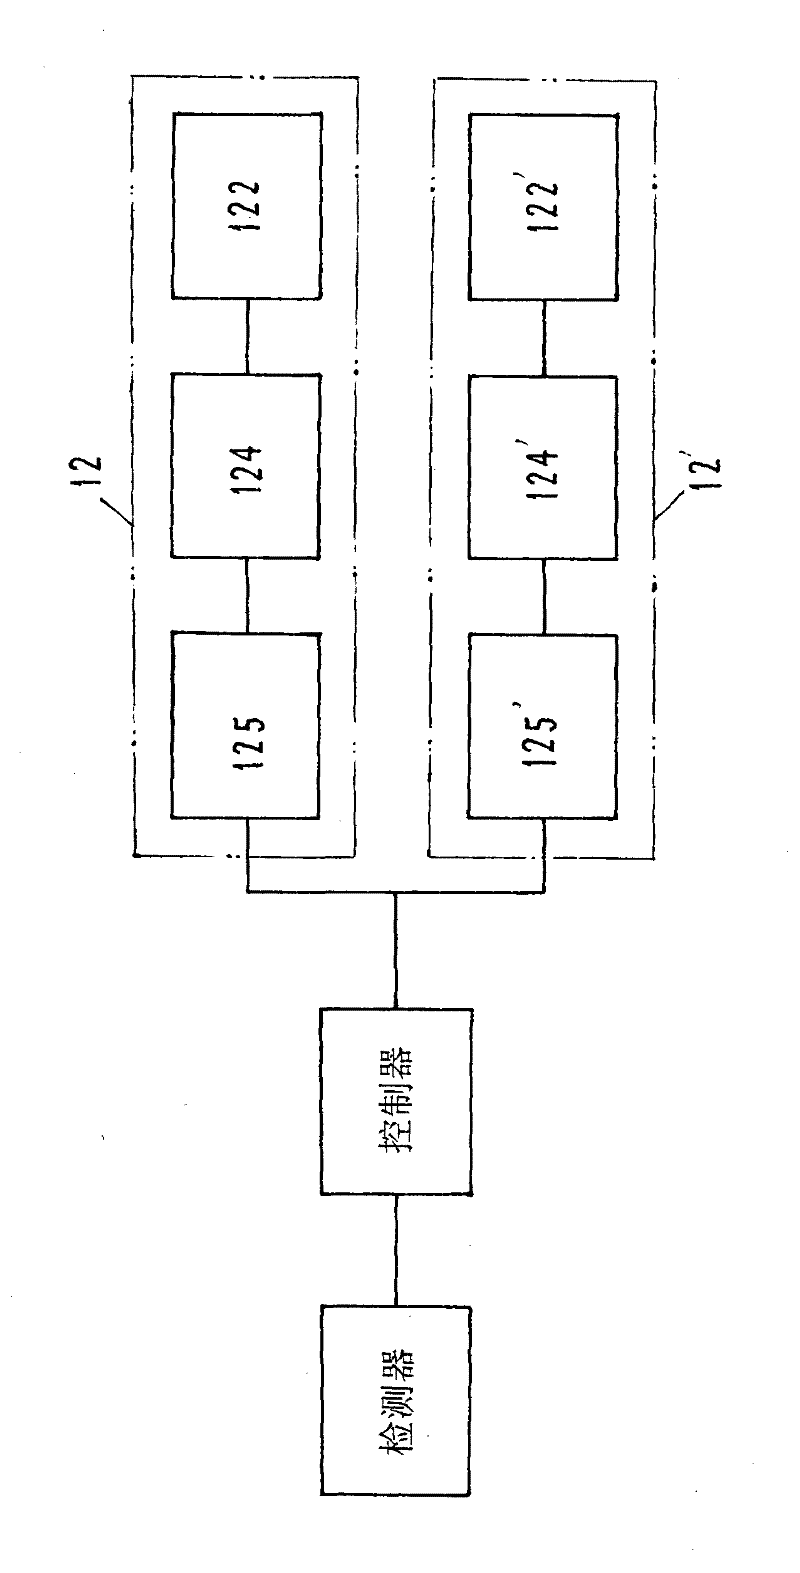
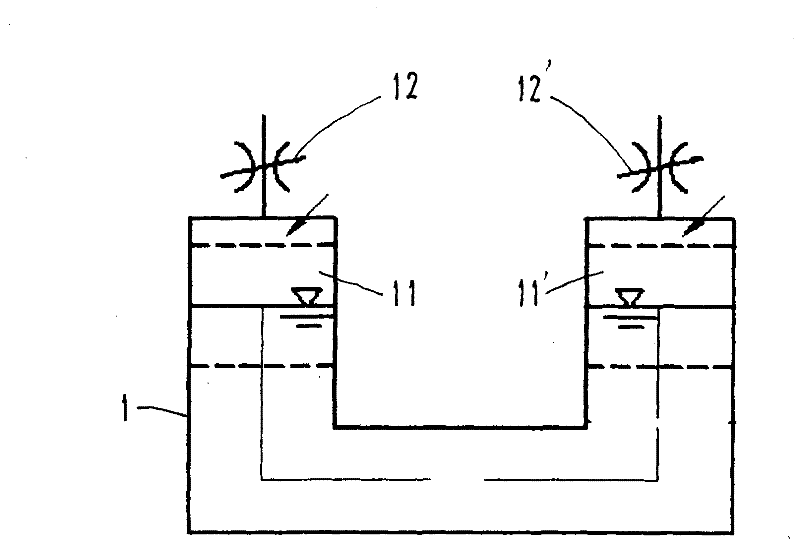
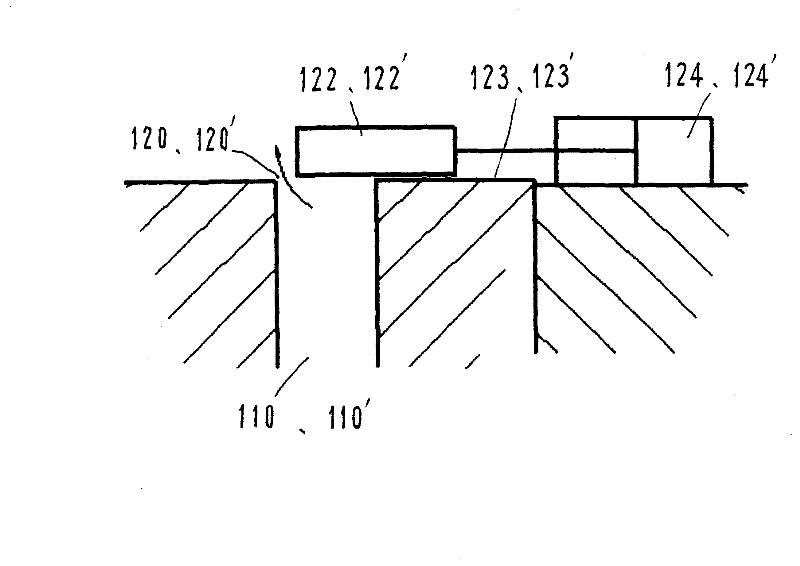
The invention discloses a tank stabilizer control device, which mainly solves the technical problems of improving the pitch damping effects of ships and the like, and adopts the technical scheme that: a left throttling passage and a right throttling passage are arranged at the top parts of a larboard air chamber and a starboard air chamber of a U-shaped tank stabilizer, throttling components are arranged on the two passages, the two components are connected with a controller which is connected with a detector, detected ship swinging period signals are input to the controller, control signals are output to the two throttling components according to set rules, and the throttling components adjust effective sectional areas of the two throttling passages so as to realize the water level alternation period of the U-shaped tank stabilizer the same as the ship swinging period. The tank stabilizer control device is applied to various U-shaped tank stabilizers.
Owner:SHANGHAI HUNTER MARINE EQUIP CO LTD
Optimization method for lowering empty rate of UUV based on NSGA-II algorithm
InactiveCN107301267AReduce vacancy rateExcellent performance indexGeometric CADInternal combustion piston enginesEngineeringA* search algorithm
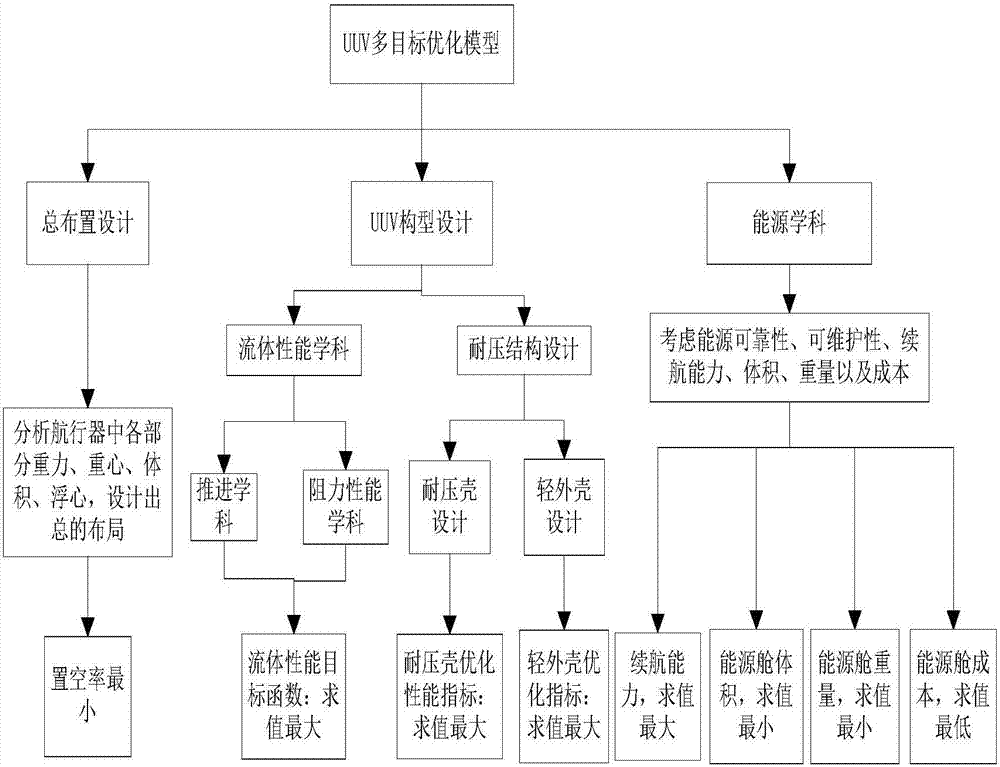
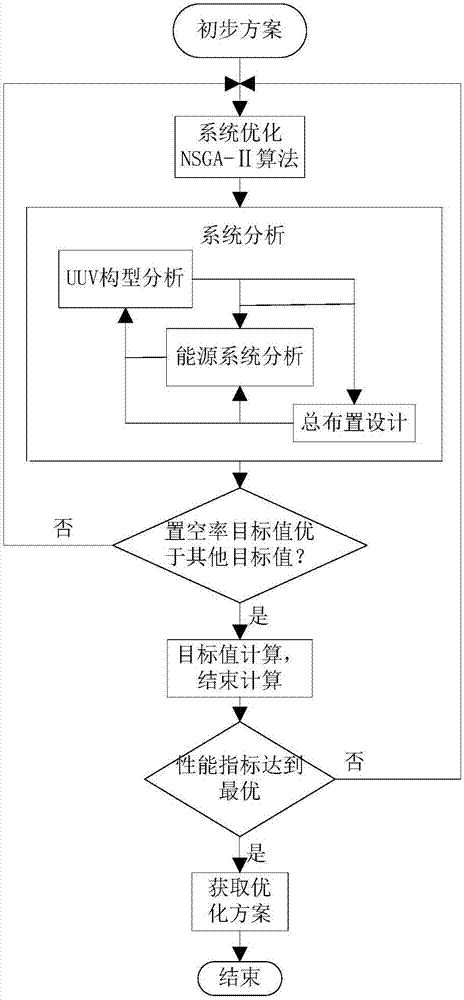
The invention belongs to the technical fields of overall performance analysis of an unmanned underwater vehicle (UUV) and multi-objective solving of an NSGA-II algorithm and particularly relates to an optimization method for lowering the empty rate of the UUV based on the NSGA-II algorithm. According to the method, a multidisciplinary optimization model of the UUV is established, an optimization objective function is clarified, overall design of the UUV is subjected to subsystem disintegration, and model design of the UUV is completed; then, by determining continuous variables and discrete variables contained in multidisciplinary optimization design, an objective function is calculated, and constraint conditions are stipulated; and finally multidisciplinary optimization is performed on the UUV according to multidisciplinary optimization design based on the NSGA-II algorithm to obtain an optimal result of the empty rate of the UUV. According to the method, the NSGA-II algorithm is selected to serve as a search algorithm for system optimization, multi-objective, multi-constraint and multi-variable actual UUV comprehensive performance problems are solved, comprehensive optimization of a typical UUV structure, performance and the empty rate of the UUV is realized, the empty rate of the UUV is lowered, good performance indicators of the UUV in all aspects are guaranteed, and therefore the method has high practicability.
Owner:HARBIN ENG UNIV
Air, water and underwater triphibious unmanned aerial vehicle
PendingCN110576713AReduce resistanceImprove sailing performanceSeaplanesAircraft convertible vehiclesPropellerEngineering
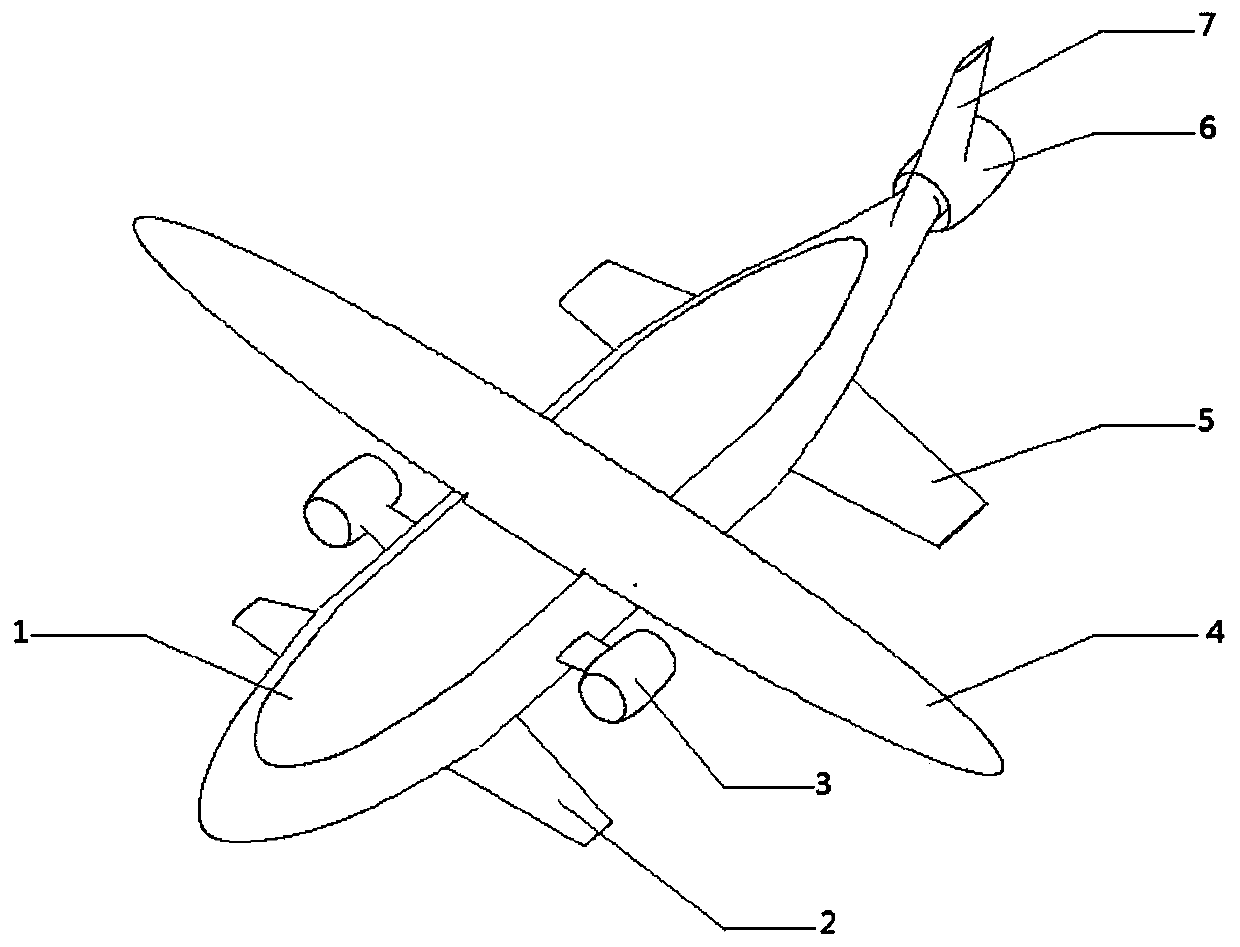
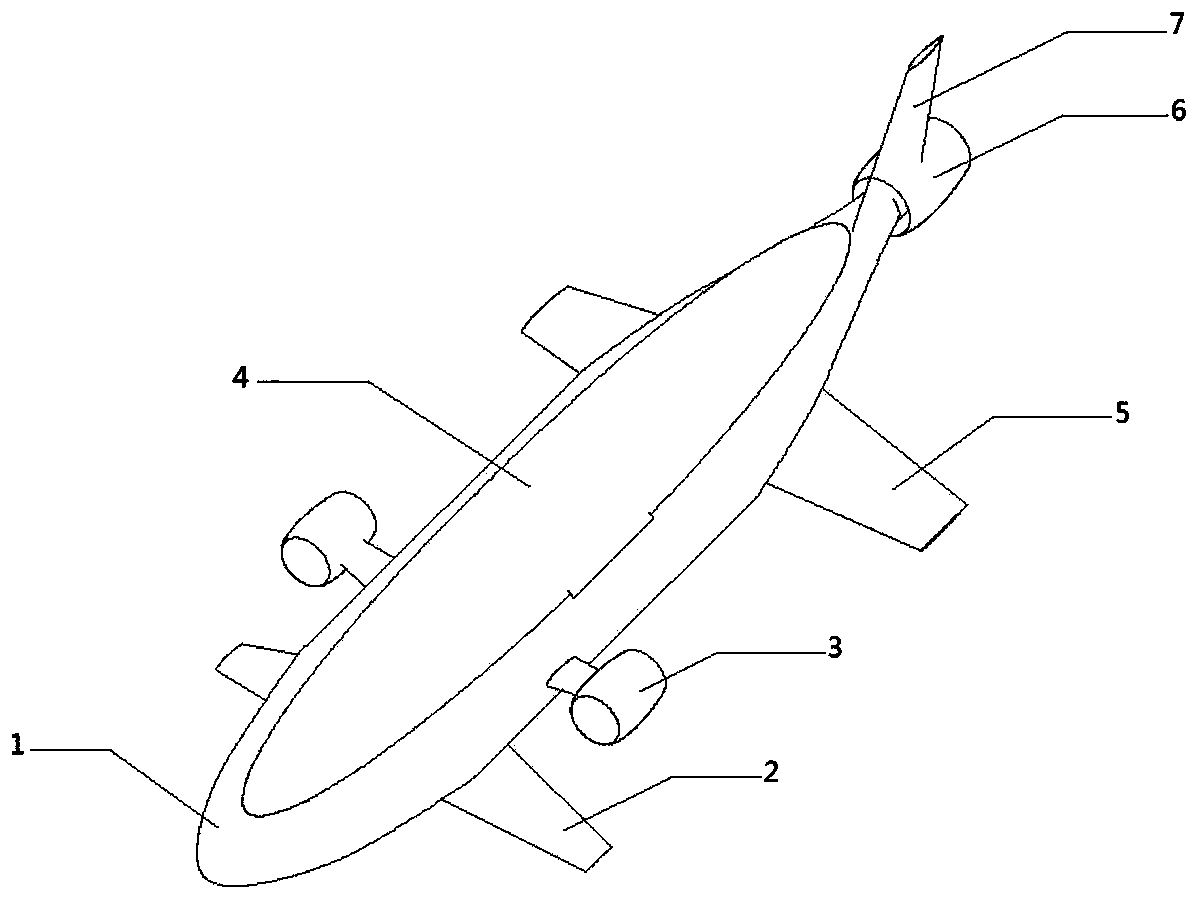
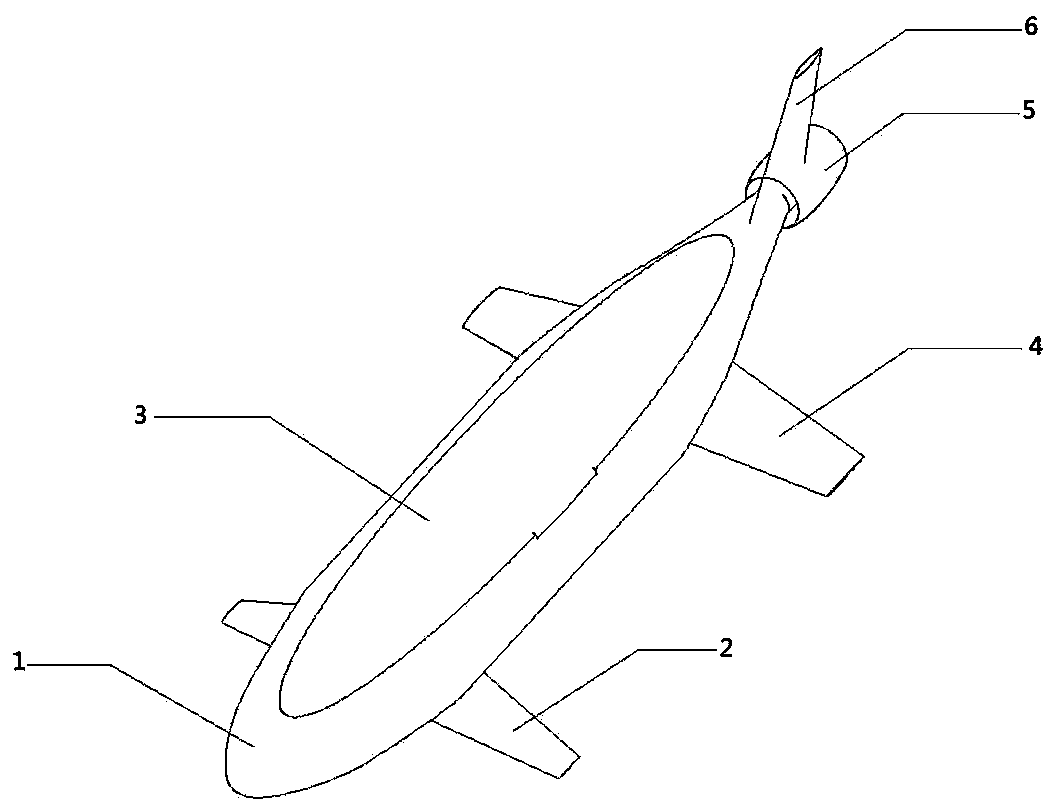
The invention discloses an air, water and underwater triphibious unmanned aerial vehicle. Through a rotatable wing and retractable ducted engines on the two sides of an unmanned aerial vehicle body, thee working modes of air flying mode, a water surface sailing mode and an underwater submerging mode are realized. In the flying mode, the wing is perpendicular to the unmanned aerial vehicle body andis locked, the unmanned aerial vehicle is as same as a three-wing-surface aircraft, a canard and horizontal tail and a control surface thereof provide longitudinal stability and operating moment forthe unmanned aerial vehicle; in the sailing mode, the wing and the unmanned aerial vehicle body are integrated to form a streamline-shaped flat spindle shape, and the canard and the horizontal tail are in contact with a water medium as hydrofoils to generate a hydrodynamic lift so that the sailing performance is improved; and in the submerging mode, the wing and the unmanned aerial vehicle body are integrated to form a streamline-shaped flat spindle shape, the ducted engines on the two sides of the unmanned aerial vehicle body are folded into the unmanned aerial vehicle body, and a tail propeller provides powder so that the unmanned aerial vehicle realizes submerging. By using a tail fin, hydrofoil and water rudder integrated design, the air, water and underwater triphibious unmanned aerial vehicle has the advantages that the structure of the unmanned aerial vehicle is optimized, the integration degree of the system is enhanced, and the structural weight and resistance of the unmannedaerial vehicle are reduced.
Owner:NORTHWESTERN POLYTECHNICAL UNIV
Anchoring device and method for UUV seabed residing
ActiveCN106741647AMaintain a streamlined appearanceAvoid displacementAnchorsAnchoring arrangementsOcean bottomSludge
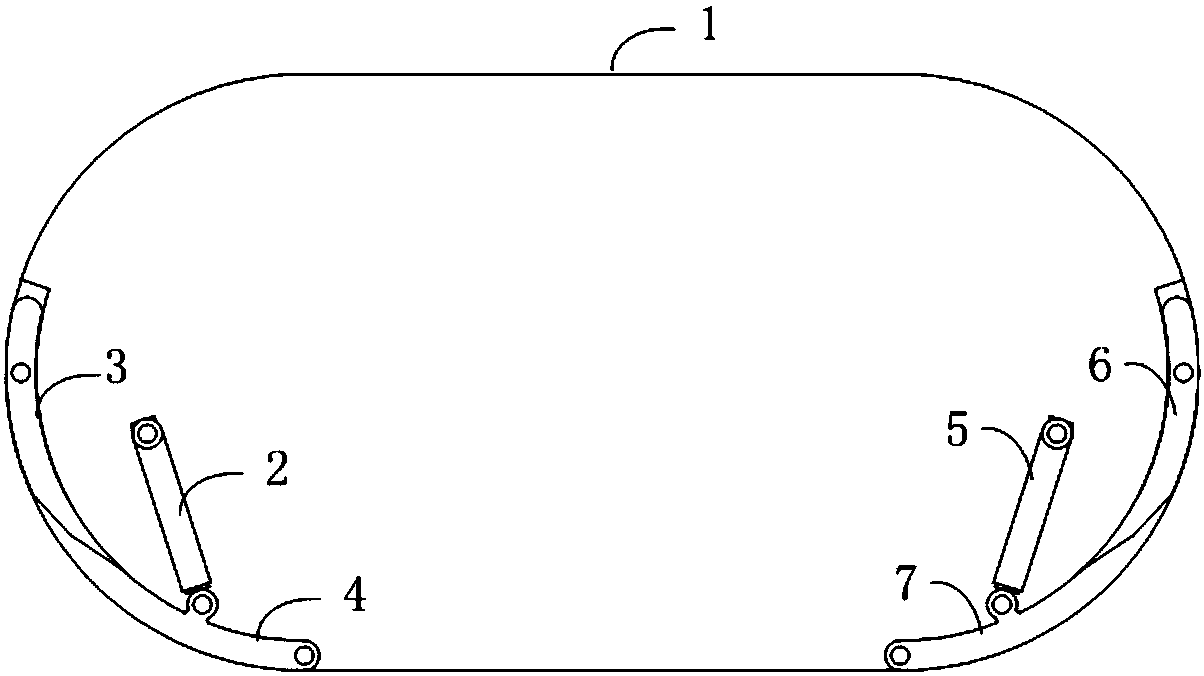
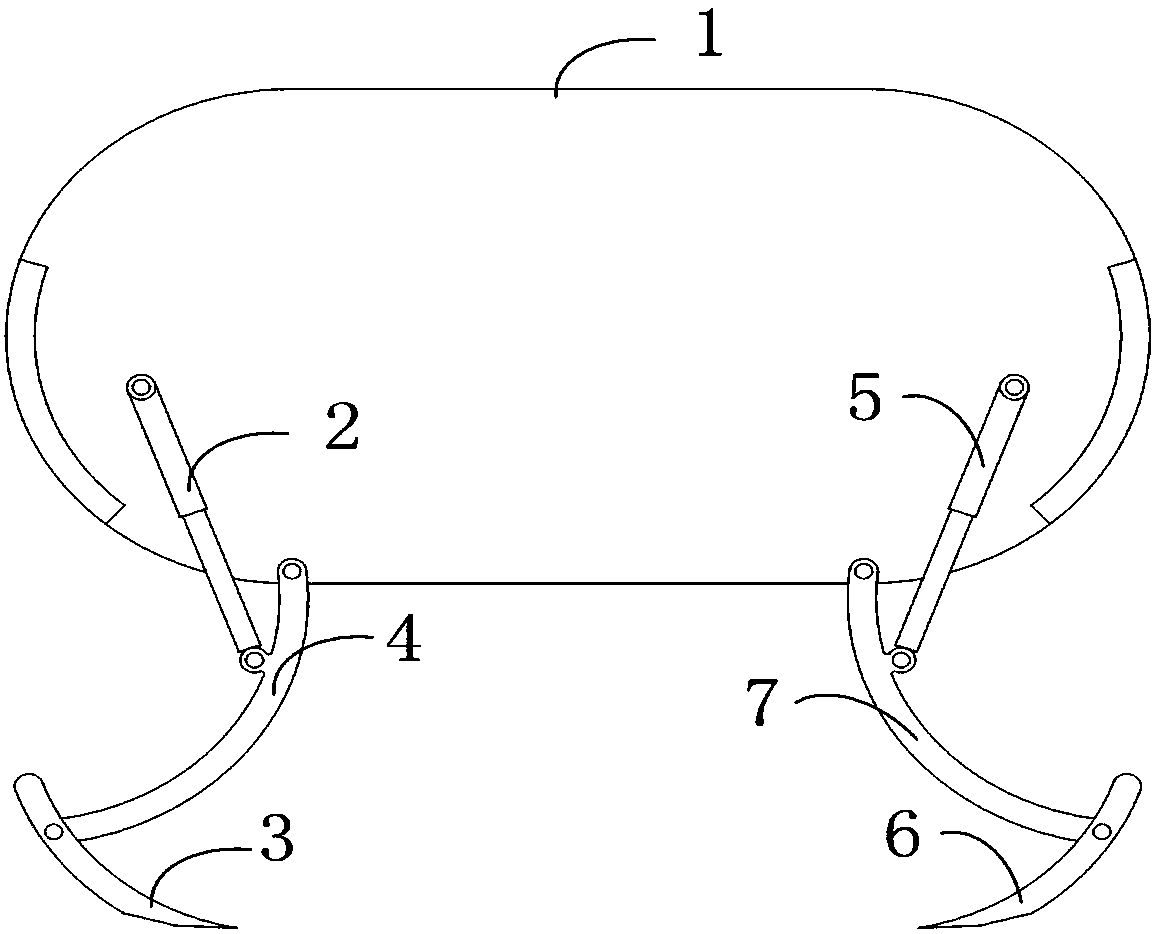
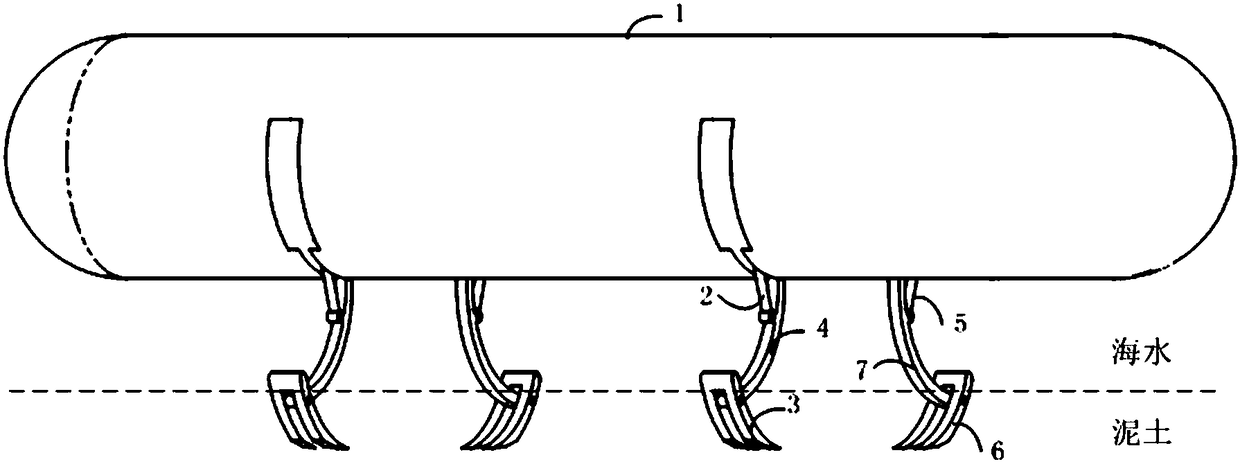
The invention provides an anchoring device and method for UUV seabed residing. The anchoring device is composed of hydraulic driving arms, retractable anchor rods and sludge grabbing shovels. In the navigation process of a UUV, each anchor rod and the corresponding sludge grabbing shovel are integrally combined and retracted at the two sides of the UUV under the action of the corresponding hydraulic driving arm to keep the streamline appearance of the UUV; when the UUV needs to reside on the seabed, the hydraulic driving arms extend to stretch out the anchor rods and the sludge grabbing shovels, and under the combined action of the hydraulic driving arms and the gravity, the sludge grabbing shovels are embedded into sludge so that the UUV stably resides on the surface of the seabed; when the UUV needs to set sail from the seabed, the hydraulic driving arms retract to drive the anchor rods and pull the sludge grabbing shovels out of the sludge, the anchor rods and the sludge grabbing shovels are retracted gradually to achieve sail setting of the UUV from the seabed. By means of the anchoring device, when resides on the seabed, the risks that the UUV shifts due to the ocean current action or buried by the sludge are avoided.
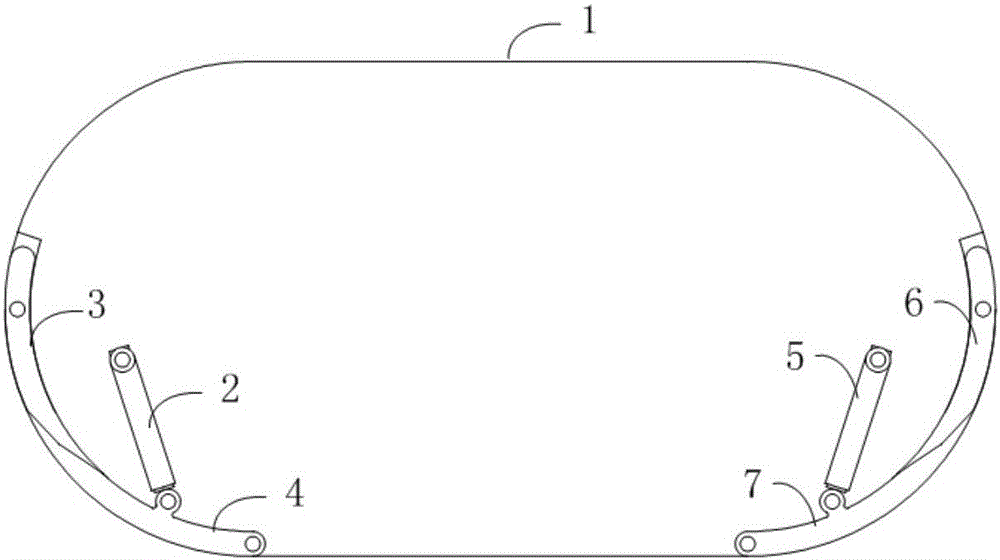
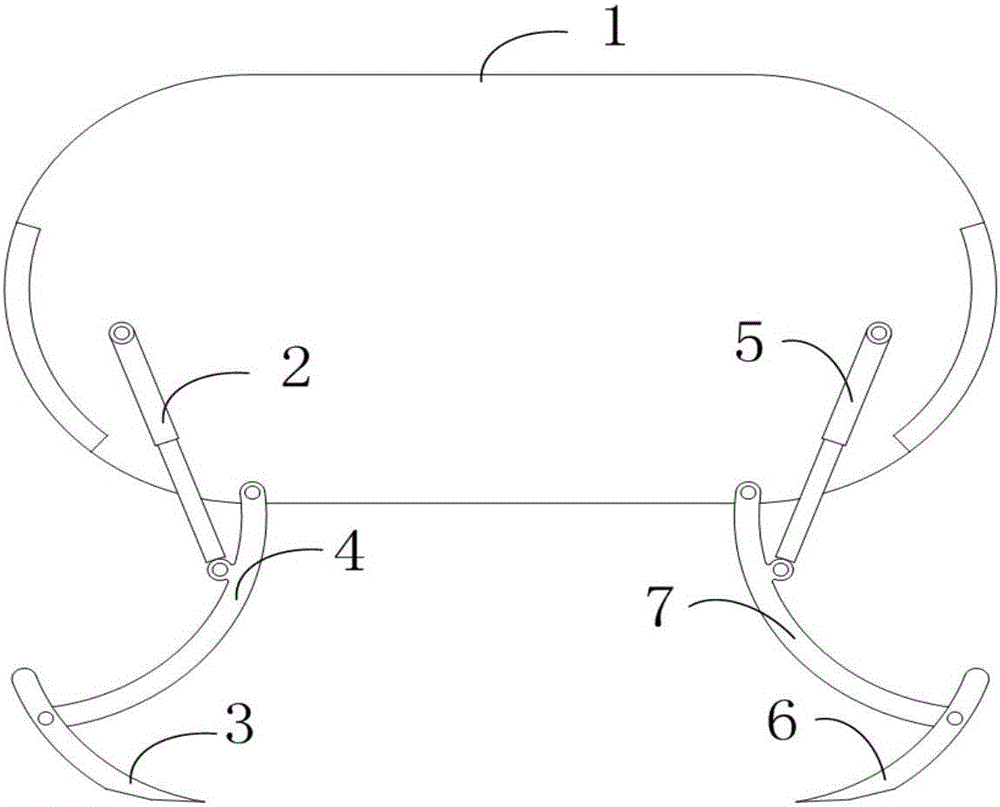
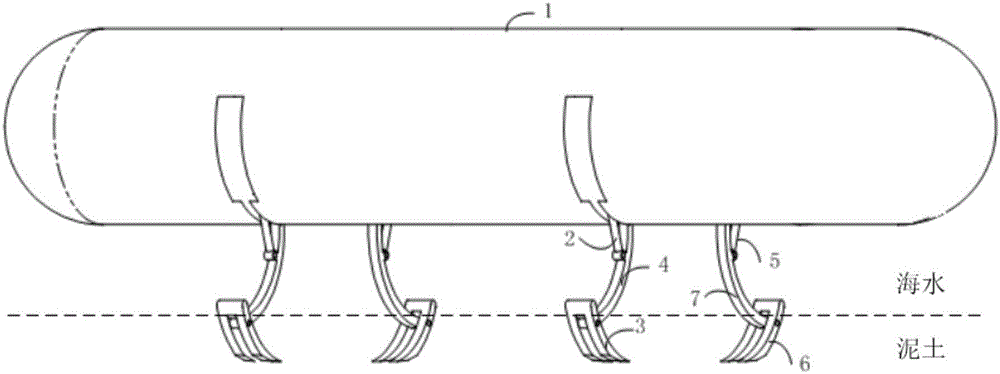
Owner:HARBIN ENG UNIV
Liquefied-gas carrying vessel
InactiveCN101855129AReduce widthReduce resistancePreventing unwanted cargo movementHull interior subdivisionMarine engineeringBeam direction
This aims to provide a liquefied-gas carrying vessel capable of reducing the width of a hull and reducing a hull resistance and a hull weight, thereby to improve a navigation performance. The liquefied-gas carrying vessel (1) comprises a plurality of spherical tanks (2) stored therein with a liquefied gas, arranged along a bow-stern direction and fixed in a hull (5) through a skirt, and one continuous tank cover (7) covering the upper halves of the spherical tanks (2) and extending along the bow-stern direction and the beam direction. The tank cover (7) is constituted such that it is rigidly jointed to the hull (5), thereby to retain the longitudinal strength integrally with the hull (5).
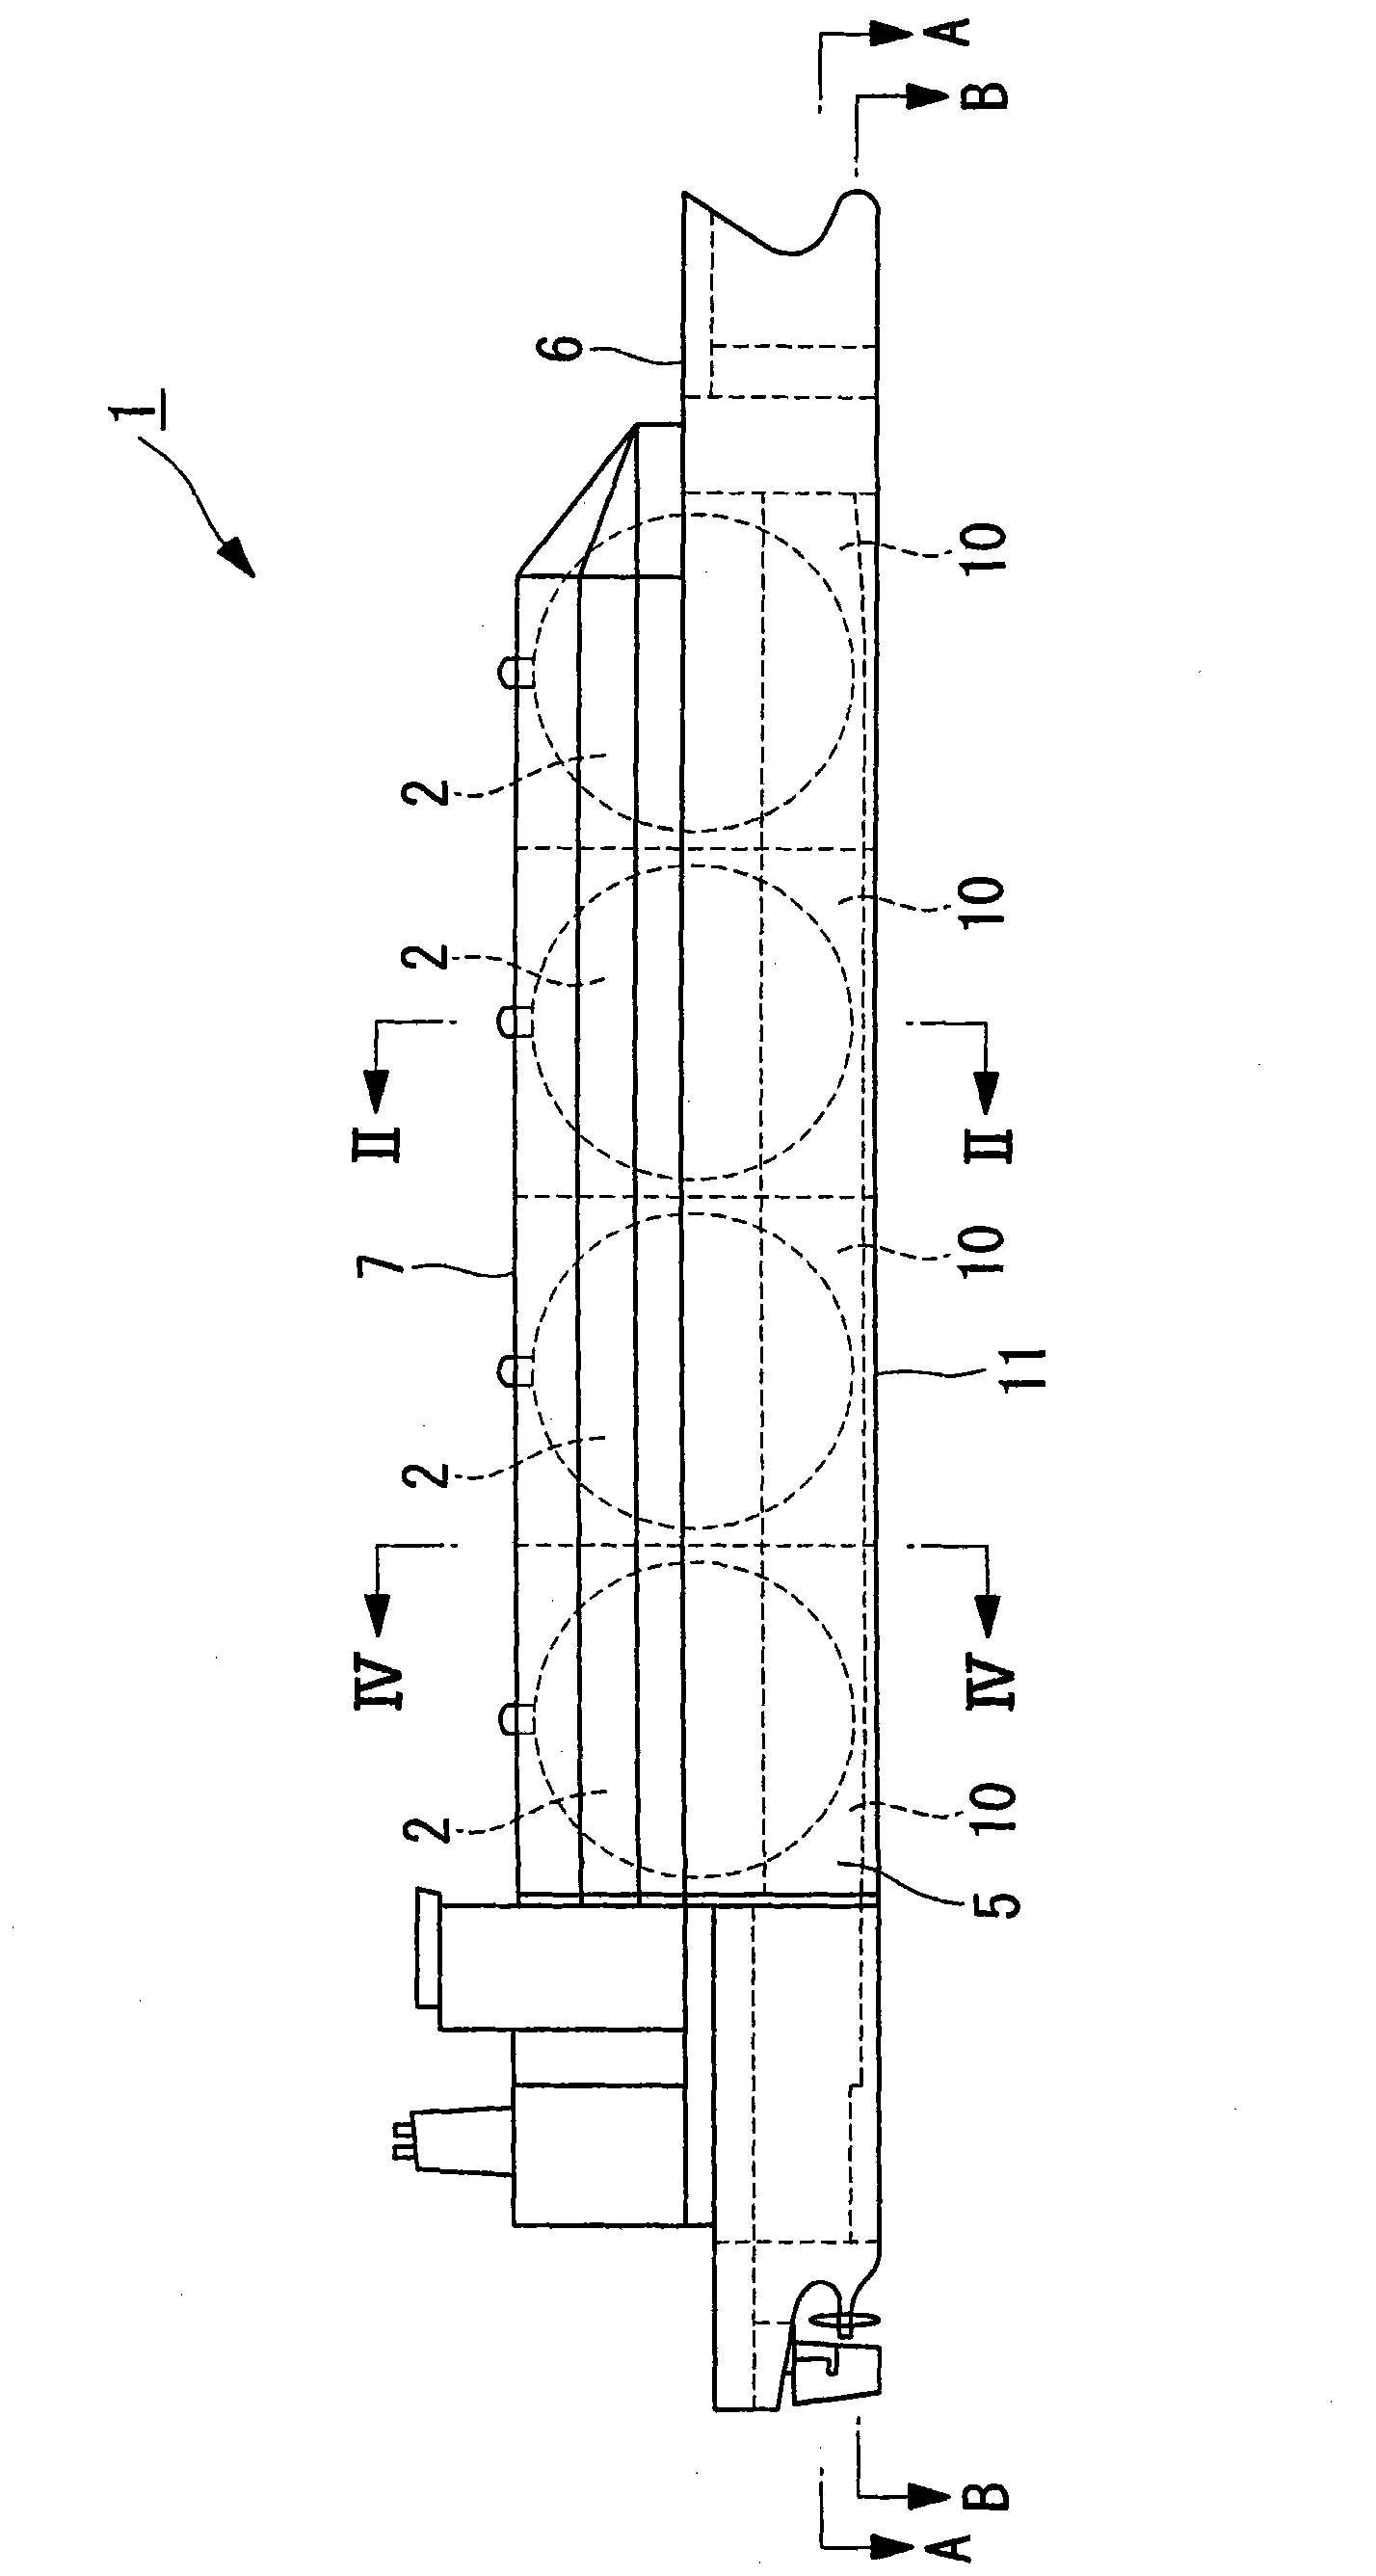
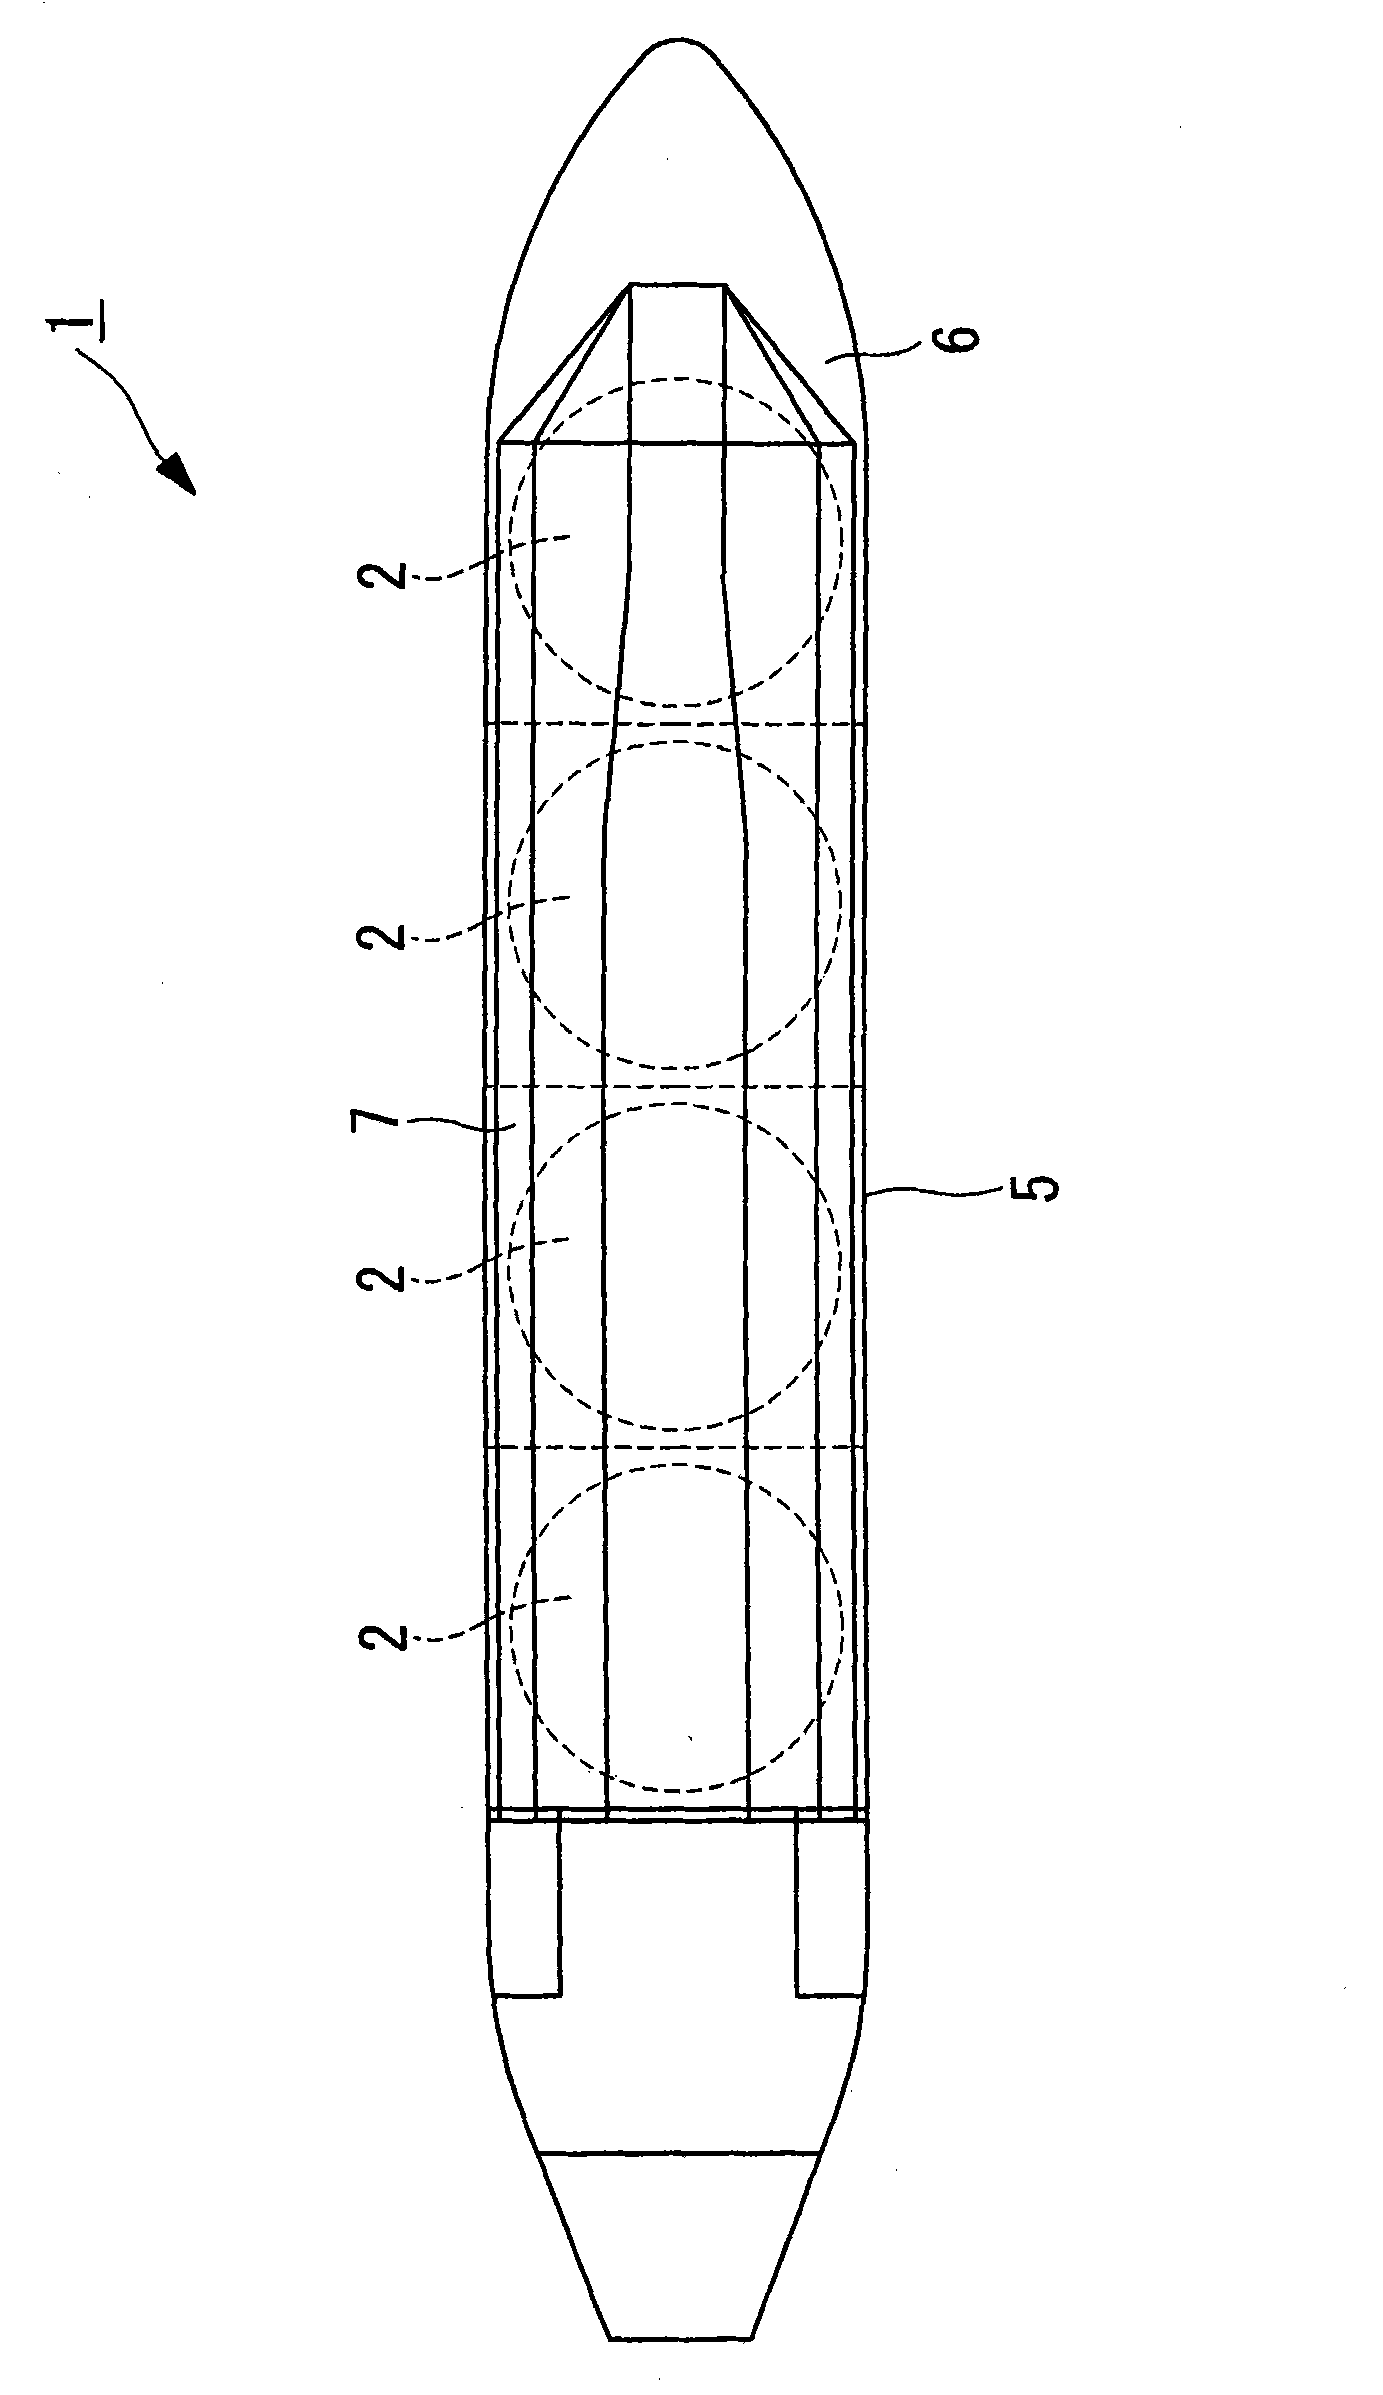
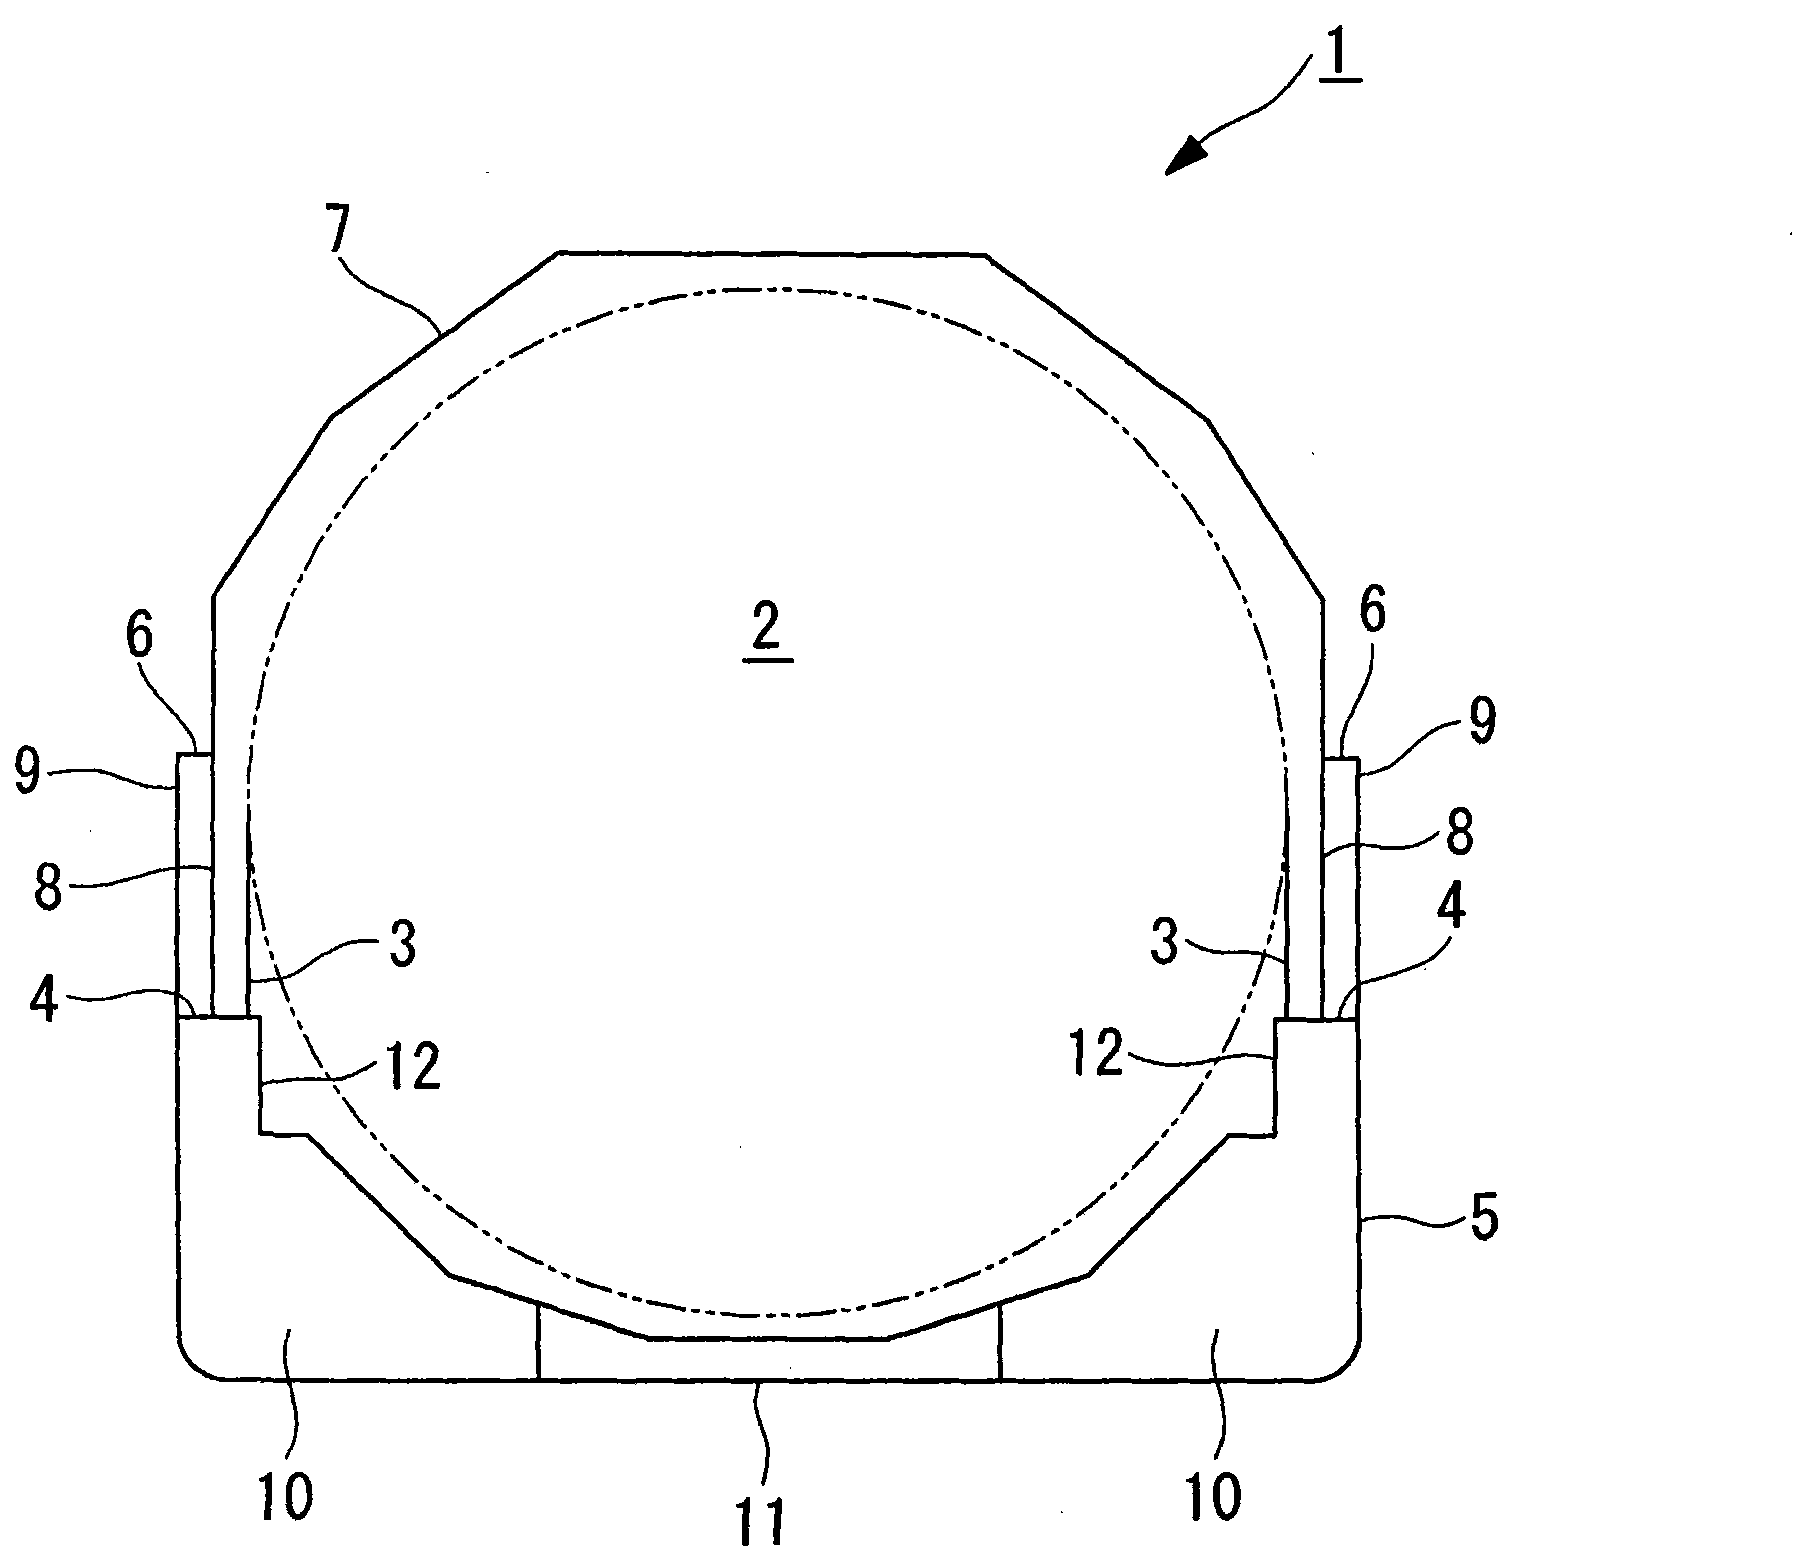
Owner:MITSUBISHI HEAVY IND LTD
Intelligent sailing/remote control unmanned working boat used for fishing of fishery
InactiveCN106516022AEliminate risks to personal life safetySimplify power configurationFishing vesselsFishingIntelligent lightingRemote control
The invention provides an intelligent sailing / remote control unmanned working boat used for fishing of the fishery to overcome deficiencies in the prior art. The intelligent sailing / remote control unmanned working boat used for fishing of the fishery comprises a power unit, lamp cabins and an unmanned boat body. By adoption of the intelligent sailing / remote control unmanned working boat with the functions of automatic sailing, intelligent navigation and full-automatic operation of boat equipment, manual fish luring on the sea is replaced, the intelligent sailing / remote control unmanned working boat is specially used for light seining fishing operation, personal life safety risks existing in traditional operation are fundamentally eliminated, and benefits of fishing of the fishery are remarkably improved; and the light seining fishing operation mode is fundamentally changed, light luring fishing boats boom, benefits of fishermen are finally improved, and the marine resources and the marine environment are better protected.
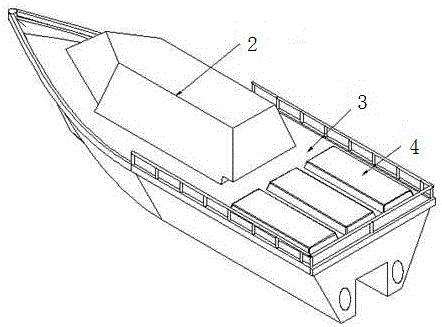
Owner:GUANGZHOU HG MARINE CO LTD
A kind of mooring device and method for uuv seabed residence
ActiveCN106741647BMaintain a streamlined appearanceAvoid displacementAnchorsAnchoring arrangementsOcean bottomSludge
The invention provides an anchoring device and method for UUV seabed residing. The anchoring device is composed of hydraulic driving arms, retractable anchor rods and sludge grabbing shovels. In the navigation process of a UUV, each anchor rod and the corresponding sludge grabbing shovel are integrally combined and retracted at the two sides of the UUV under the action of the corresponding hydraulic driving arm to keep the streamline appearance of the UUV; when the UUV needs to reside on the seabed, the hydraulic driving arms extend to stretch out the anchor rods and the sludge grabbing shovels, and under the combined action of the hydraulic driving arms and the gravity, the sludge grabbing shovels are embedded into sludge so that the UUV stably resides on the surface of the seabed; when the UUV needs to set sail from the seabed, the hydraulic driving arms retract to drive the anchor rods and pull the sludge grabbing shovels out of the sludge, the anchor rods and the sludge grabbing shovels are retracted gradually to achieve sail setting of the UUV from the seabed. By means of the anchoring device, when resides on the seabed, the risks that the UUV shifts due to the ocean current action or buried by the sludge are avoided.
Owner:HARBIN ENG UNIV
Buffering self-electricity-generating type wave propeller
InactiveCN107100786AReduce fatigue damageReduce wave impact damageMachines/enginesEngine componentsElectricityPropeller
The invention discloses a buffering self-electricity-generating type wave propeller and belongs to the field of underwater propeller designs. The buffering self-electricity-generating type wave propeller comprises a connecting device, a power device, a buffering self-electricity-generating device and an upper floating body. The buffering self-electricity-generating device is fixed at the bottom of the upper floating body. The power device is in active connection with the buffering self-electricity-generating device through the connecting device. The buffering self-electricity-generating device is composed of a transmission connecting rod, an electric energy output wire, a magnetic piston, an induction coil, limiting springs and a shell. The upper floating body makes heaving motion under stimulation of wave force, relative motion is produced between the power device and the upper floating body, and a flexible cable connecting the upper floating body with the power device produces transient tensile force and stores wave energy in a mode of elastic potential energy of the limiting springs. The transforming pattern of the wave energy is increased, the utilization efficiency of the wave energy is improved, wave impacting damage borne by a wave glider is reduced, the service life of the wave glider is prolonged, the total electricity supply amount is increased, and the requirement of the wave glider for long-endurance operation is met.
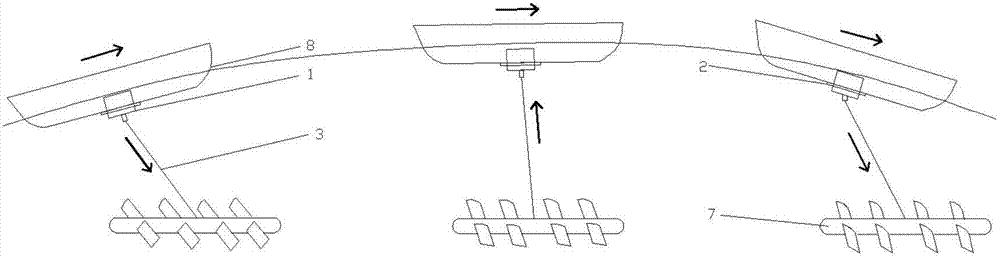
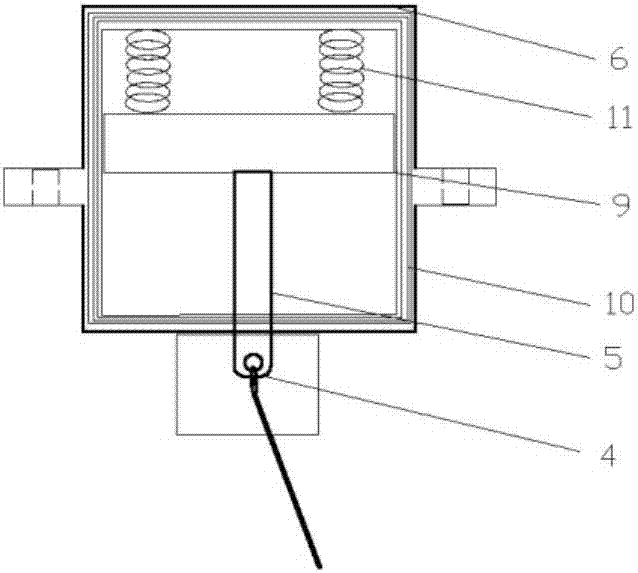
Owner:HARBIN ENG UNIV
Dual draft crane vessel
InactiveUS8960116B2Reduced roll motionEasy to adaptPipe laying and repairVessel partsMarine engineeringKeel
Vessel including a hull of a substantially closed surface has at deck level a lifting crane, ballast tanks within the hull and a ballast control unit for admitting water to the ballast tanks for changing the draft of the vessel. The hull has a narrow lower section having first width over a height from keel level to a widening level, and a top section having a larger width than the lower section, extending from the widening level upwards towards deck level. The control unit is adapted to ballast the vessel to have a relatively shallow draft level in a transit mode, so that the wide top section is above water level, while the vessel is traveling, and to ballast the vessel to a relatively deep draft level in a lifting mode so that the widening level is below water level, at least when the vessel is substantially stationary and the crane is in its lifting position.
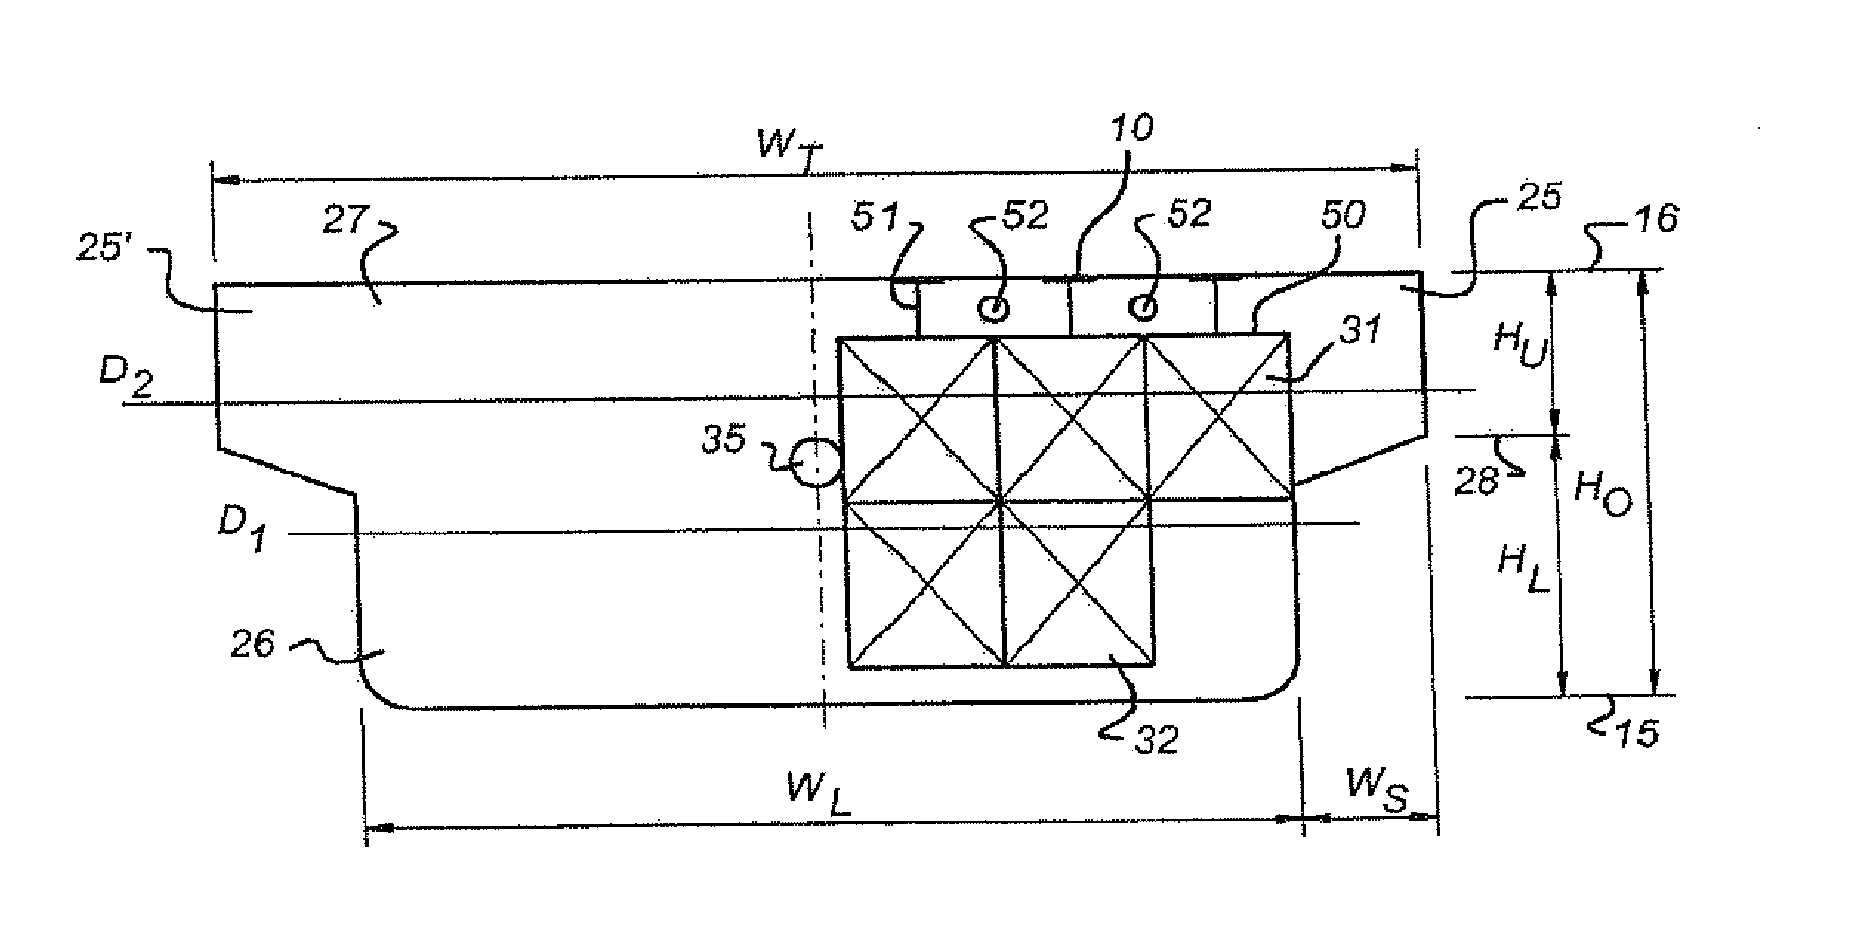
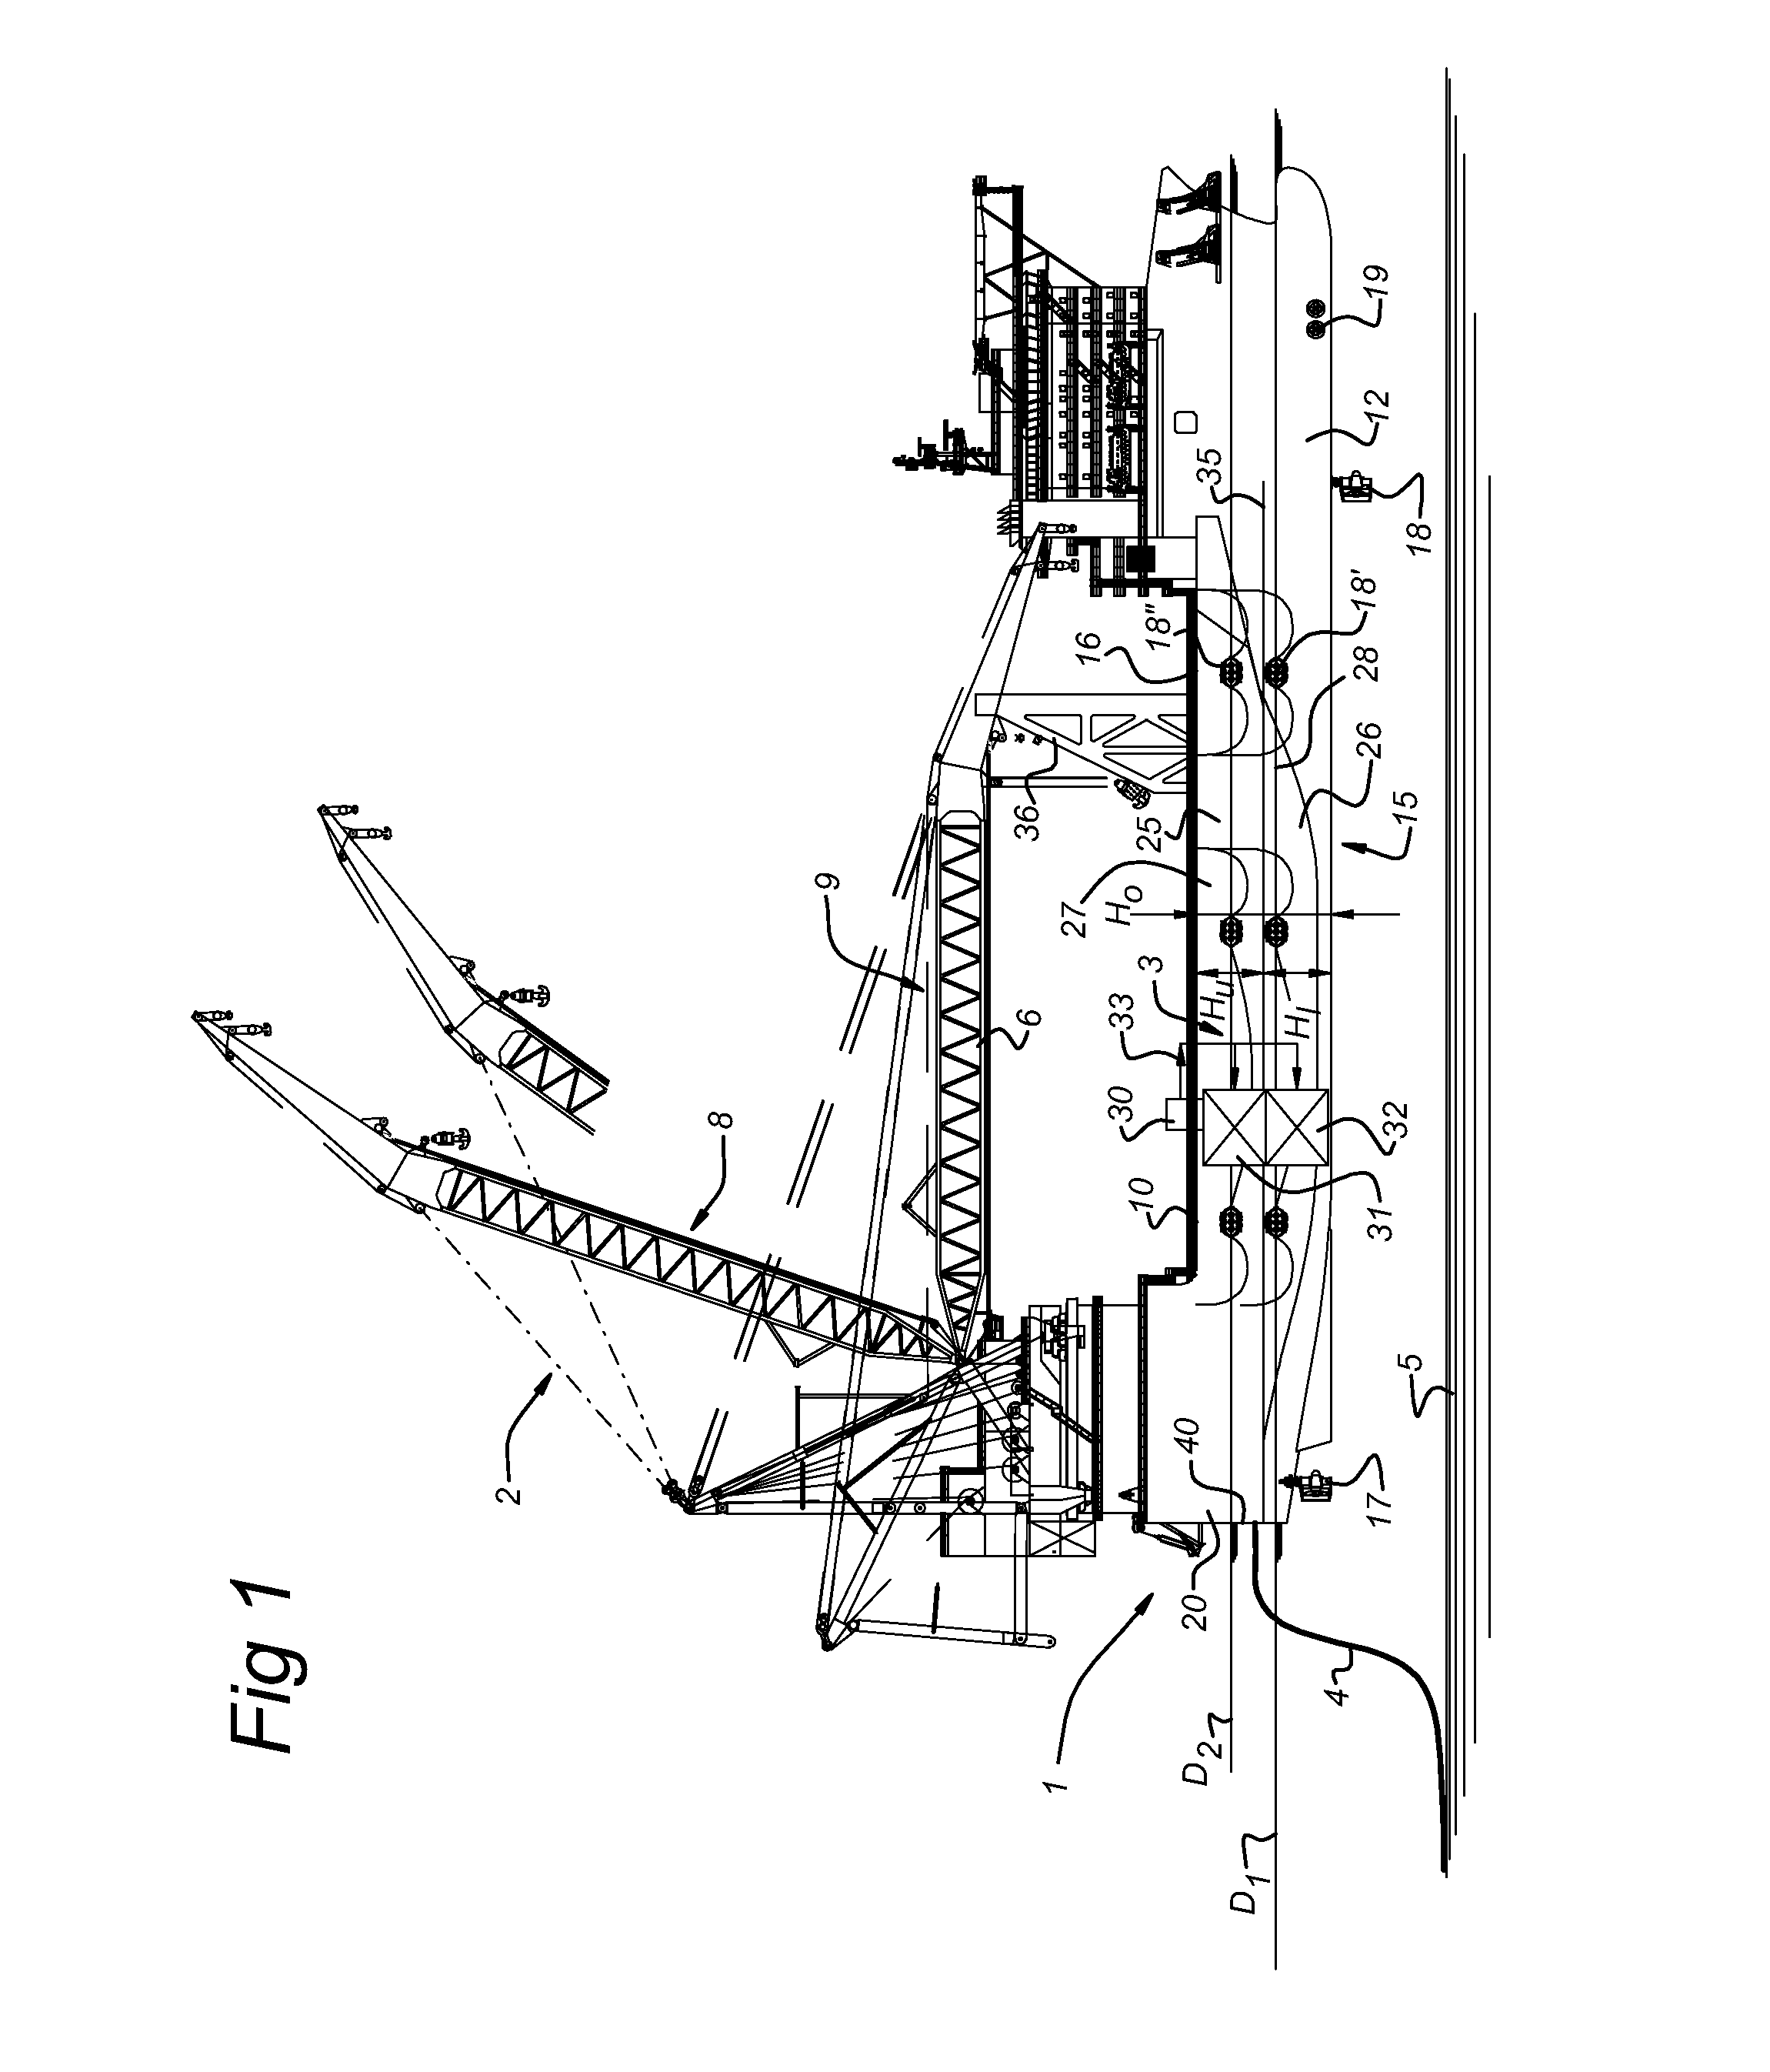
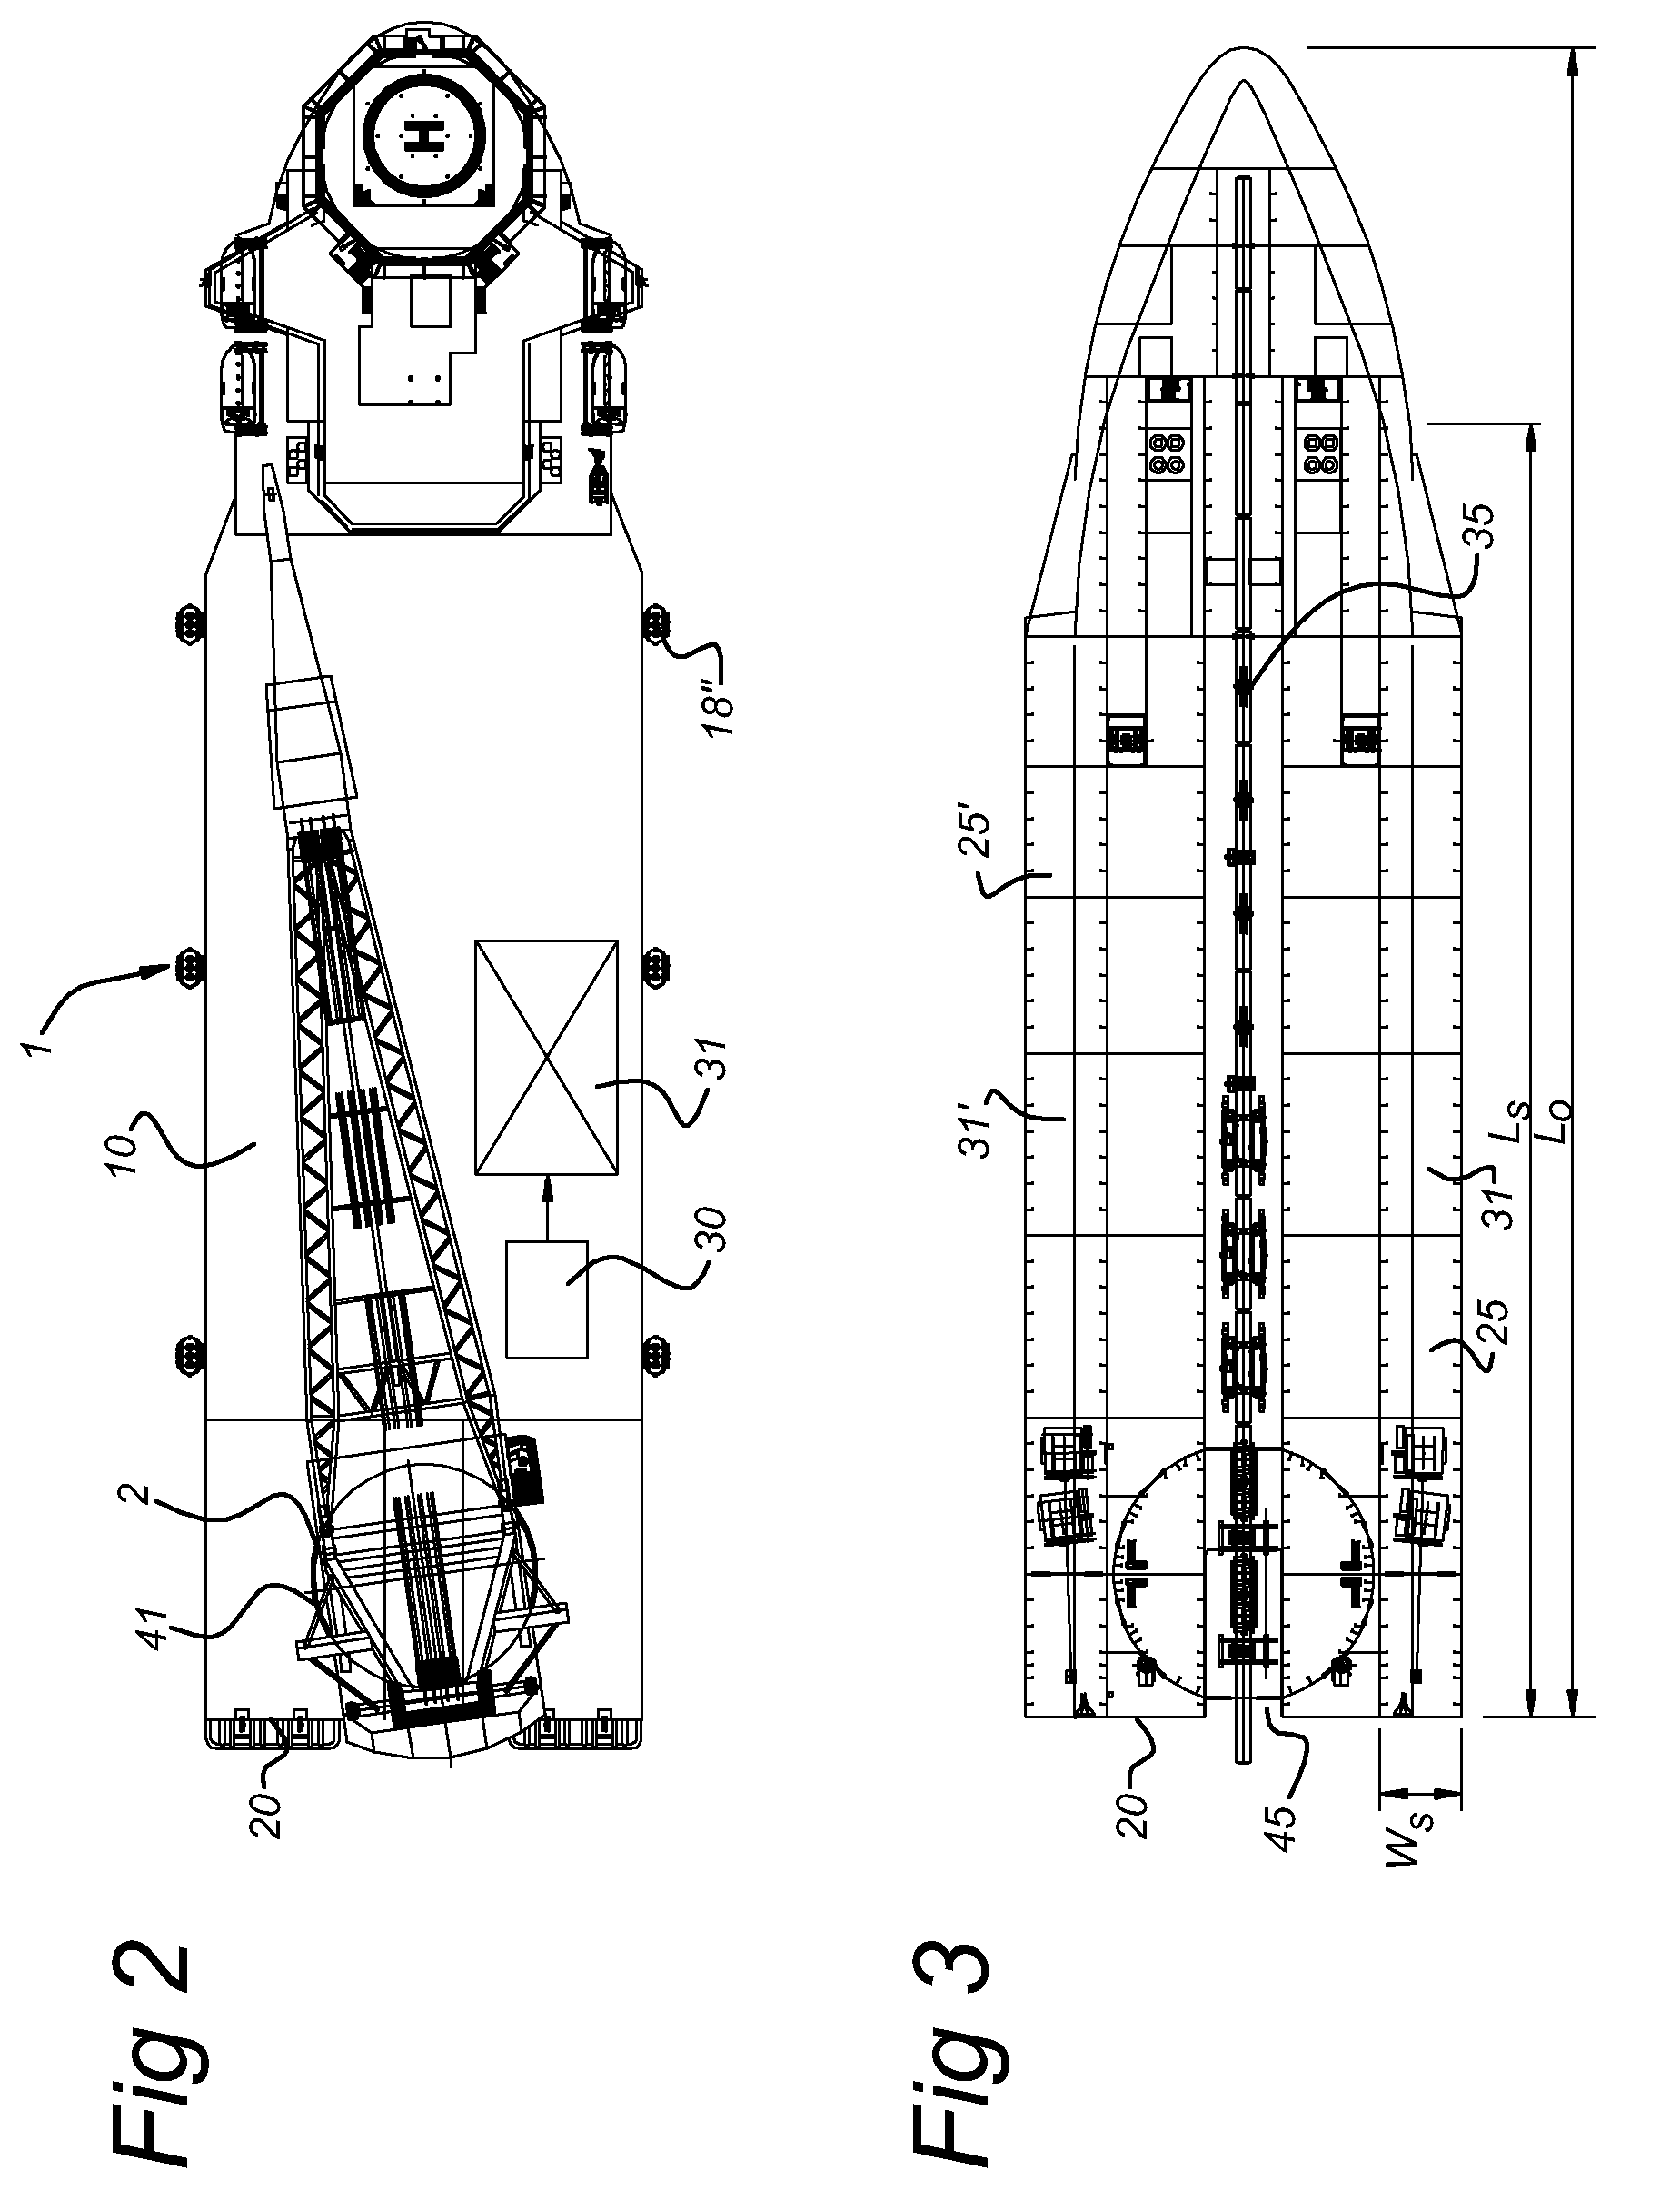
Owner:GUSTOMSC RESOURCES BV +1
Folded antenna arrangement for AUV
PendingCN112018488AReduce sailing resistanceImprove workabilityAntenna supports/mountingsAntenna adaptation in movable bodiesUnderwater navigationMarine engineering
The invention discloses a folding antenna device for an AUV. The invention aims to solve the problem that when an AUV sails underwater, an antenna of a traditional AUV is still kept in an upright state and becomes AUV sailing resistance, so that the sailing distance is reduced. According to the scheme, the sliding block connecting rod mechanism is used for achieving the antenna folding function, the overall structural design is novel, the device moving size is small, no redundant appendage exists during underwater navigation, and appendage resistance can be completely reduced; the AUV with theimproved design reduces the sailing resistance in water to the maximum extent, and can be used as an innovative mechanism design of a long-voyage AUV.
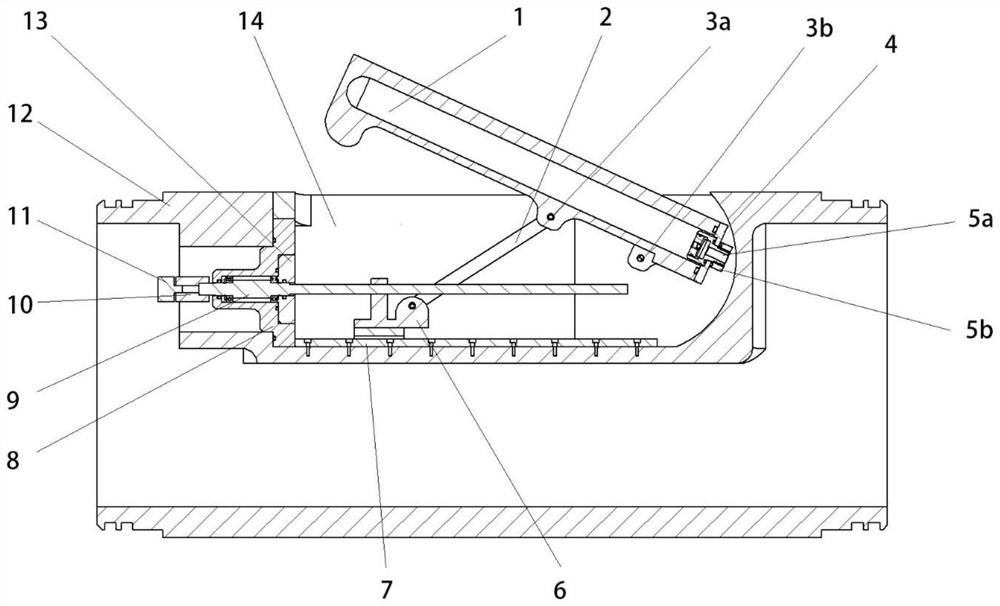
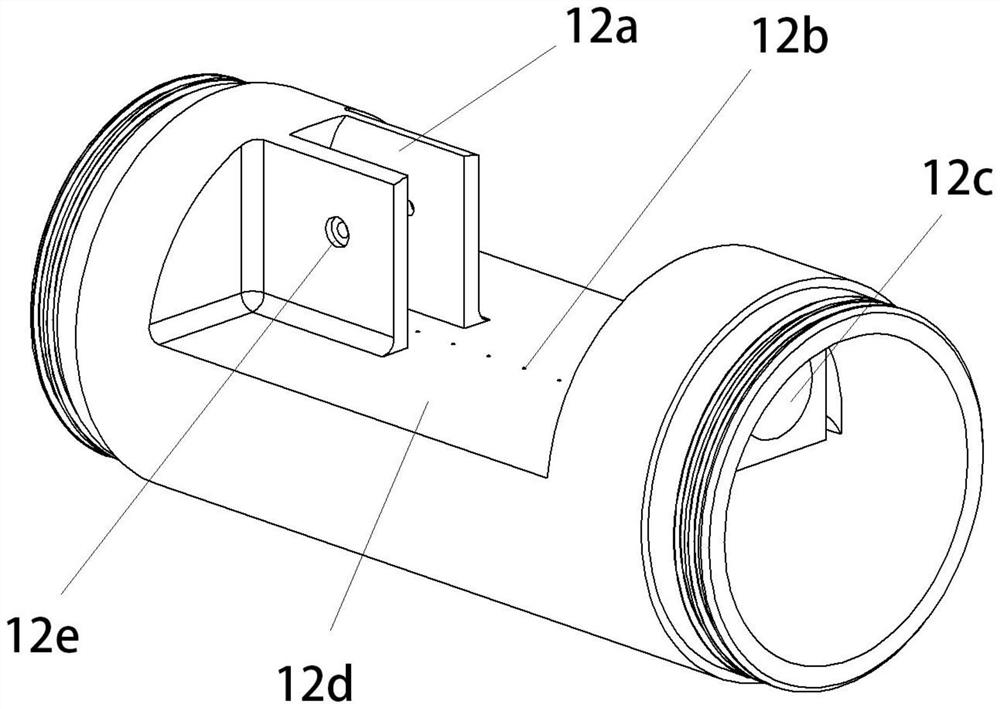
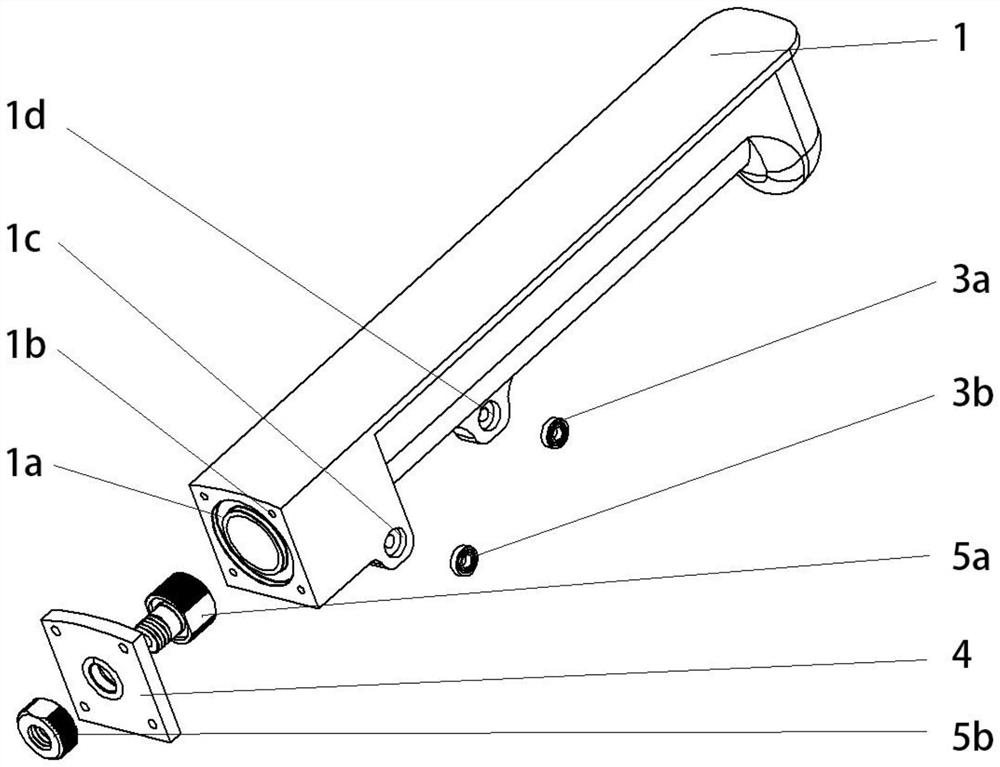
Owner:CHINA JILIANG UNIV
Green energy, small waterplane and improved catamaran unmanned boat for marine environmental monitoring
ActiveCN109606578AReduce waves and interference resistanceReduce wave resistanceUnmanned surface vesselsVessel safetyIntelligent control systemDecision-making
The invention discloses a green energy, small waterplane and improved catamaran unmanned boat for marine environmental monitoring. The unmanned boat includes a superstructure, a small waterplane improved double-sheet body main boat body, a boat body monitoring and motion intelligent control system, a navigation planning and decision-making system, and an environmental monitoring system. The unmanned boat adopts a small waterplane catamaran as a carrier, optimal calculation is performed in boat type parameters of the small waterplane catamaran by comprehensive optimization software, a scheme with best navigation performance for a main function of marine meteorological monitoring is obtained, wave-making and interference resistance between sheet bodies are effectively reduced, through combination of the advantages of small wave-making resistance, large deck area, good wave resistance, small navigation resistance and good stability of the small waterplane catamaran itself, a stable working environment can be provided for various monitoring equipment, and its better navigation performance can meet working requirements of the unmanned boat in offshore and distant sea water areas.
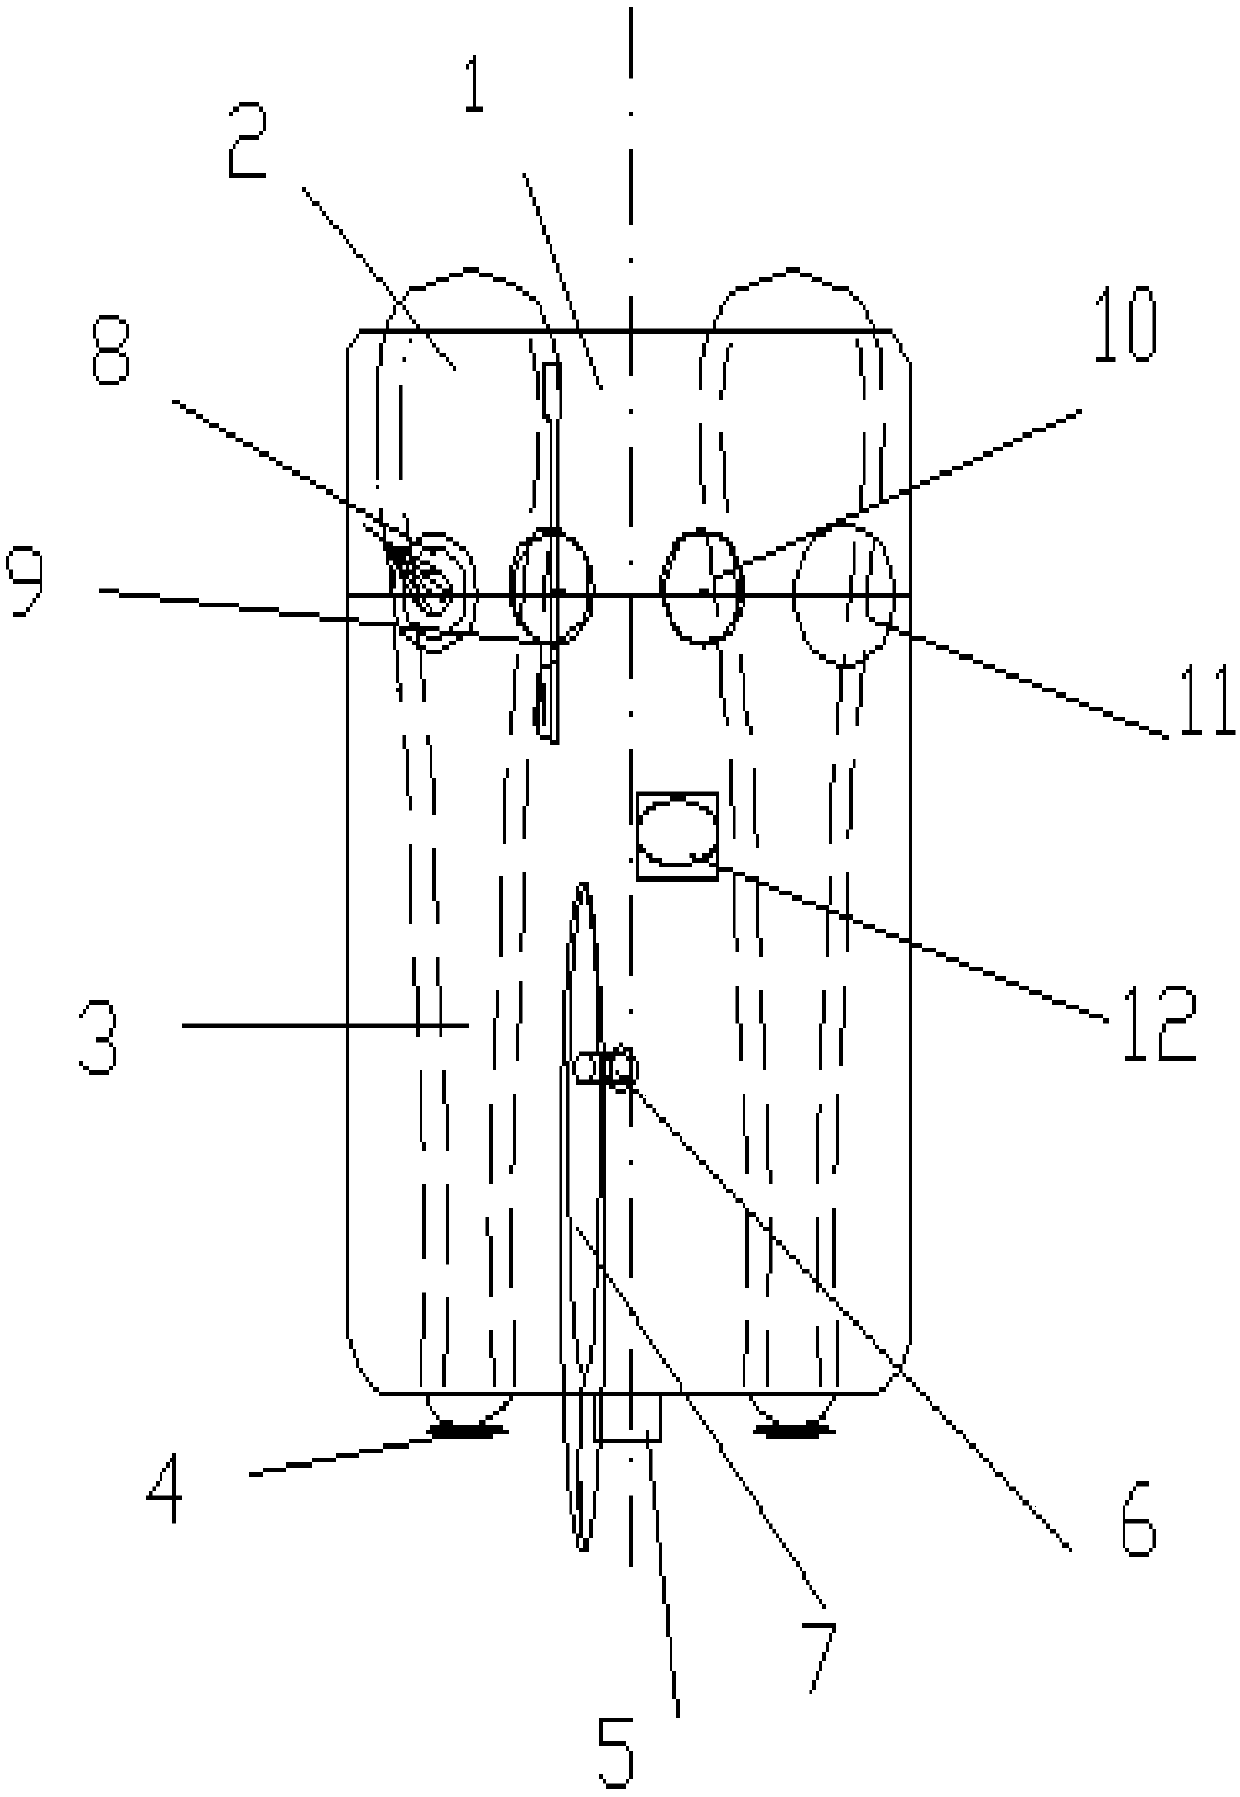
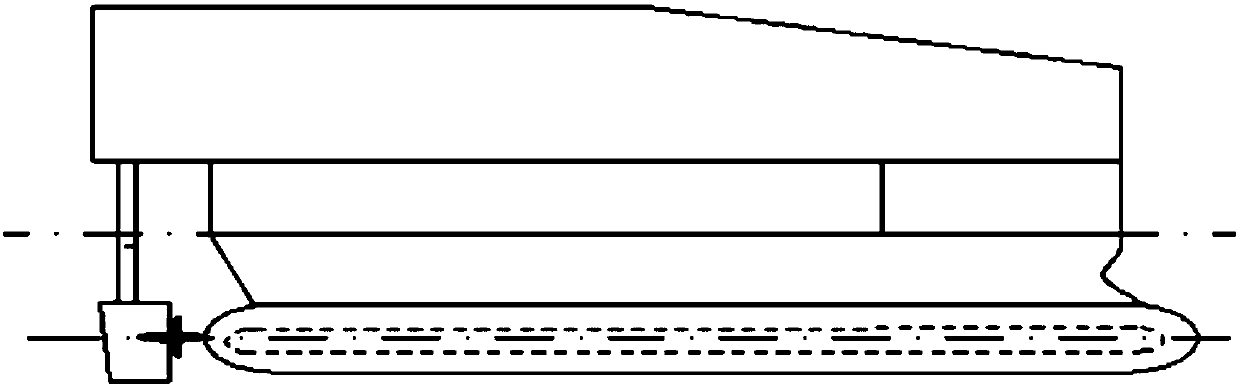
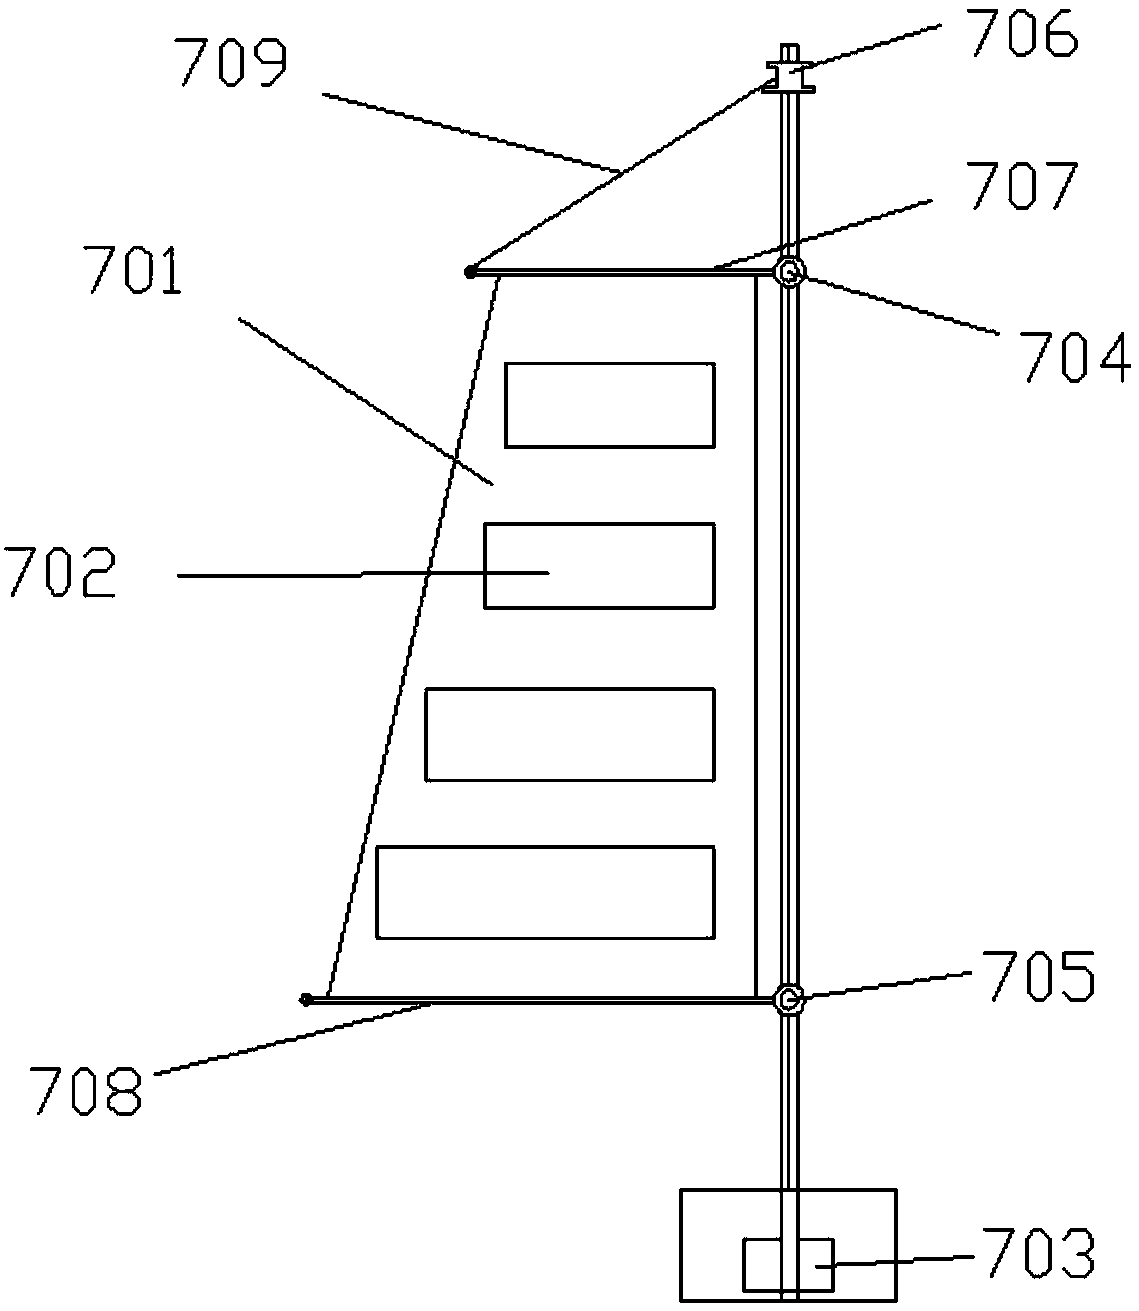
Owner:JIANGSU UNIV OF SCI & TECH
Liquefied-gas carrying vessel
InactiveCN104816791AReduce widthReduce resistancePreventing unwanted cargo movementHull interior subdivisionMarine engineeringBeam direction
This aims to provide a liquefied-gas carrying vessel capable of reducing the width of a hull and reducing a hull resistance and a hull weight, thereby to improve a navigation performance. The liquefied-gas carrying vessel (1) comprises a plurality of spherical tanks (2) stored therein with a liquefied gas, arranged along a bow-stern direction and fixed in a hull (5) through a skirt, and one continuous tank cover (7) covering the upper halves of the spherical tanks (2) and extending along the bow-stern direction and the beam direction. The tank cover (7) is constituted such that it is rigidly jointed to the hull (5), thereby to retain the longitudinal strength integrally with the hull (5).
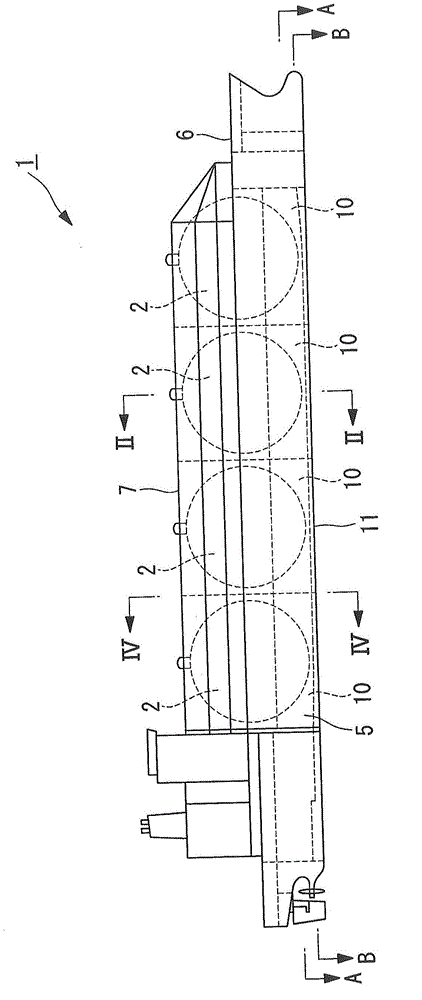
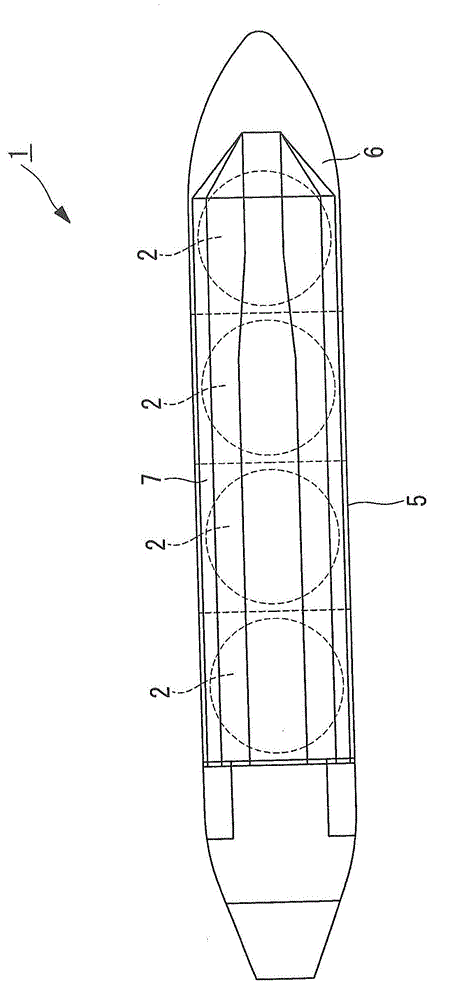
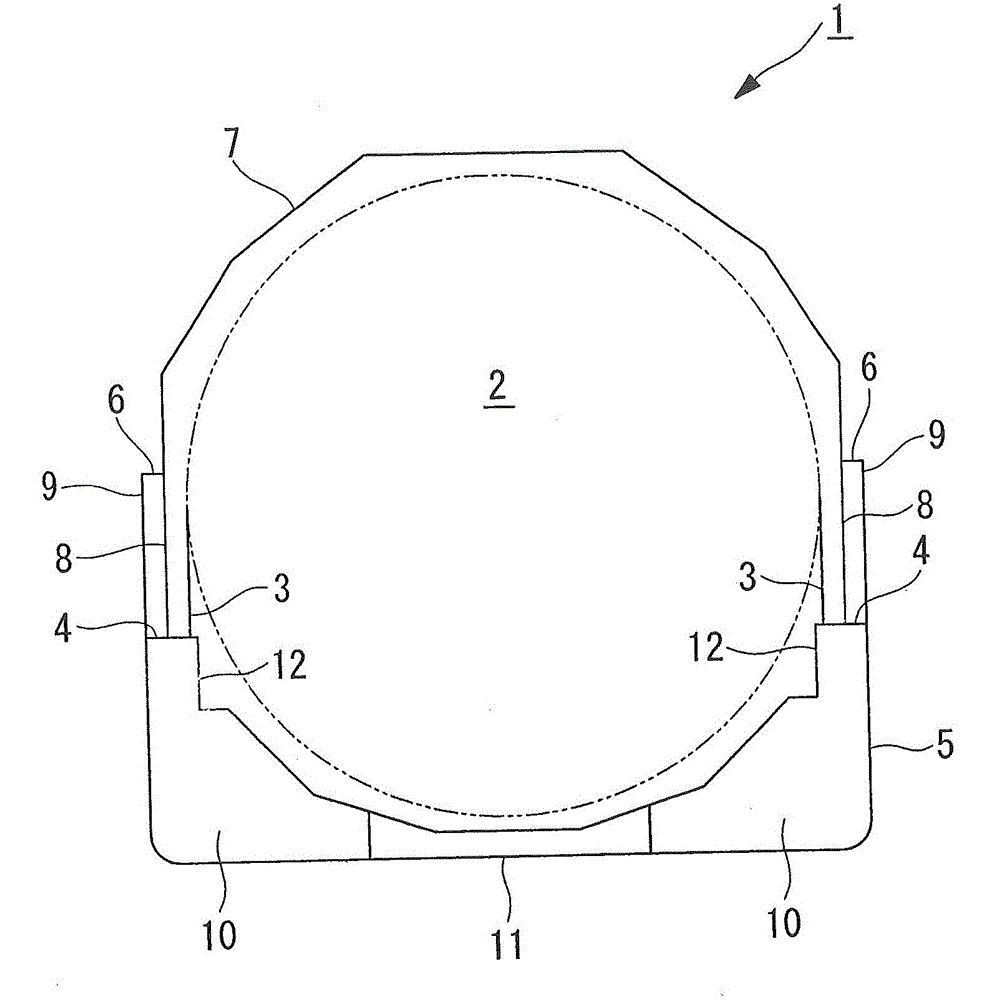
Owner:MITSUBISHI SHIPBUILDING CO LTD
Amphibious unmanned aerial vehicle structure
ActiveCN109110111AImprove versatilityMeet the needs of takeoff and landing operationsFloatsWheel arrangementsControl systemUncrewed vehicle
The invention relates to an amphibious unmanned aerial vehicle structure, which comprises a fuselage, bearing columns, at least two undercarriages, a plurality of liquid level sensors, at least two ranging devices and a falling adaptive control system, wherein the undercarriages are connected with the lower surface of the fuselage through the bearing columns; the two ends of the bearing columns are separately hinged to the fuselage and the undercarriages through rotating table mechanisms; the liquid level sensors are uniformly distributed on the outer surface of each undercarriage; the liquidlevel sensors on the same undercarriage are uniformly distributed in a straight line direction where the upper end surfaces of the undercarriages are vertically distributed; the ranging devices are uniformly distributed on the lower end surface of the fuselage in the axial direction of the fuselage; the axes of the ranging devices and a horizontal plane are vertically distributed; and each undercarriage comprises a road wheel, a buoy, a jet pump and a jet nozzle. On one hand, the requirement that unmanned aerial vehicle equipment takes off from and lands to the land and a water surface can bemet, and on the other hand, the unmanned aerial vehicle equipment has relatively high navigation capacity on the water surface.
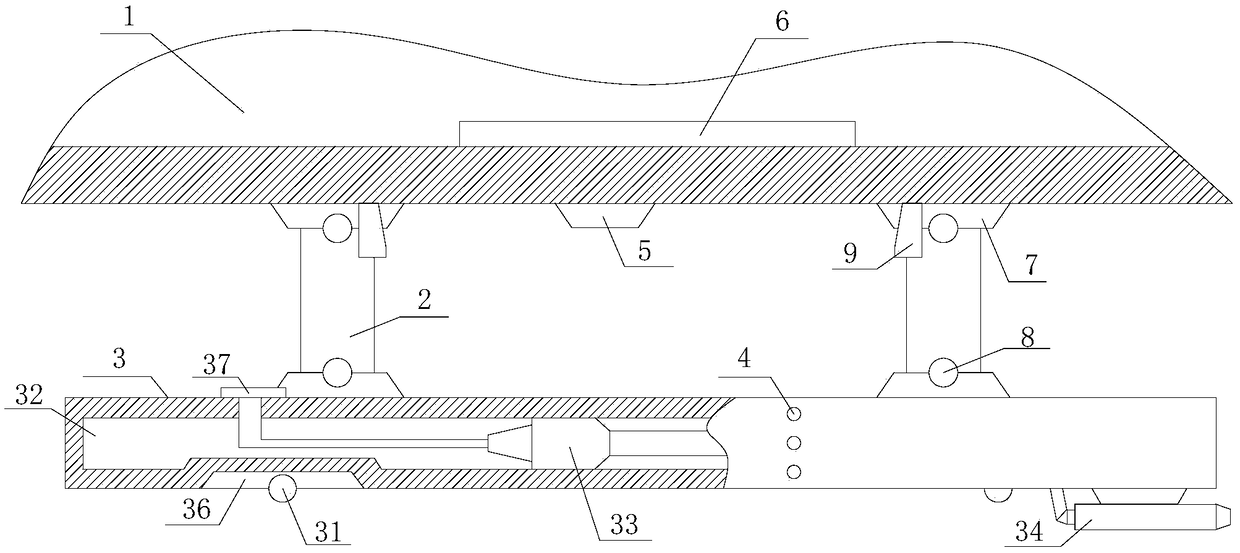
Owner:JINING XINRUIDA INFORMATION TECH CO LTD
Water jet propulsion wheel type amphibious unmanned ship
InactiveCN109367333AReduce resistanceImprove sailing performanceAmphibious vehiclesFront-wheel driveBattery pack
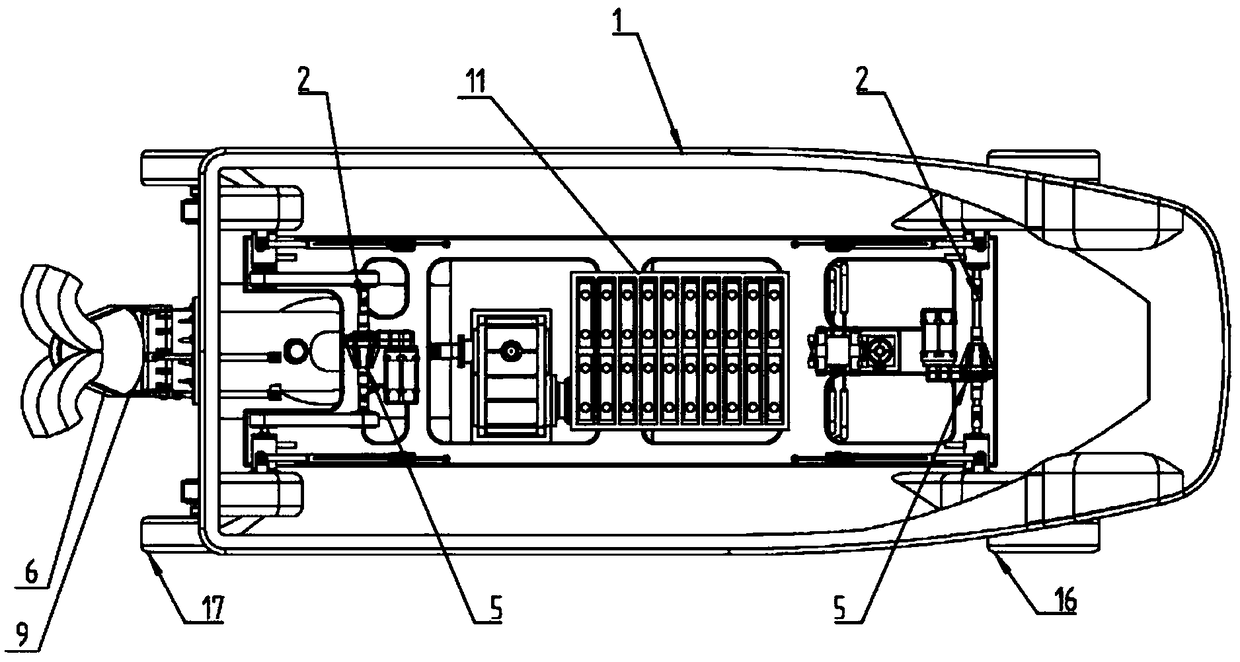
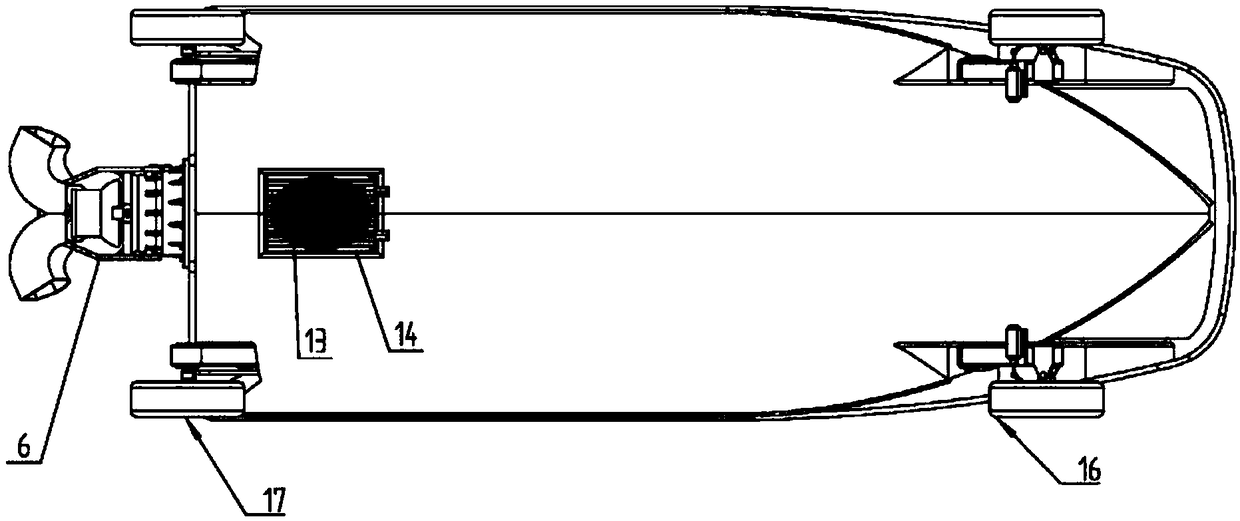
The invention discloses a water jet propulsion wheel type amphibious unmanned ship which is characterized by comprising a ship body, a battery pack, a water jet propulsion device and a wheel type walking device. The battery pack, the water jet propulsion device and the wheel type walking device are arranged on the ship body; the wheel type walking device comprises a drive unit, at least one frontwheel drive unit, a pair of back wheel drive units, at least one tire steering unit and a tire reeling unit; the front wheel drive unit and the back wheel drive units are rotatably arranged on corresponding positions of the front side and the back side of the ship body; a tire is rotatably arranged on the front wheel drive unit through the tire steering unit; a tire is rotatably arranged on each back wheel drive unit; an output shaft of the drive unit is connected with input shafts of the front wheel drive unit and the back wheel drive units; output shafts of the front wheel drive unit and theback wheel drive units are connected with axles of the tires; and the tire reeling unit drives the front wheel drive unit and the back wheel drive units to rotate around rotation axes of the tire drive units. The water jet propulsion wheel type amphibious unmanned ship provided by the invention has a favorable shallow water through capacity aiming at the shallow water environment.
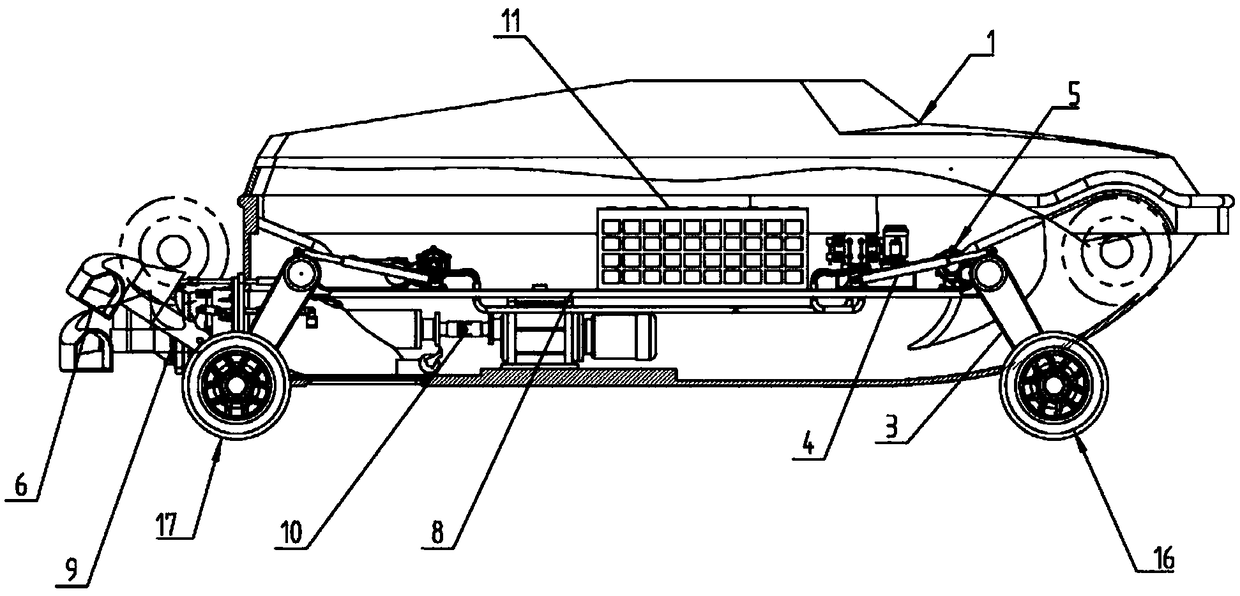
Owner:HOHAI UNIV
Multi-underwater-robot cooperative ocean current estimation method
PendingCN110749890AImprove sailing performanceIncreased complexityFluid speed measurementAcoustic wave reradiationVelocity measurementNon linear estimation
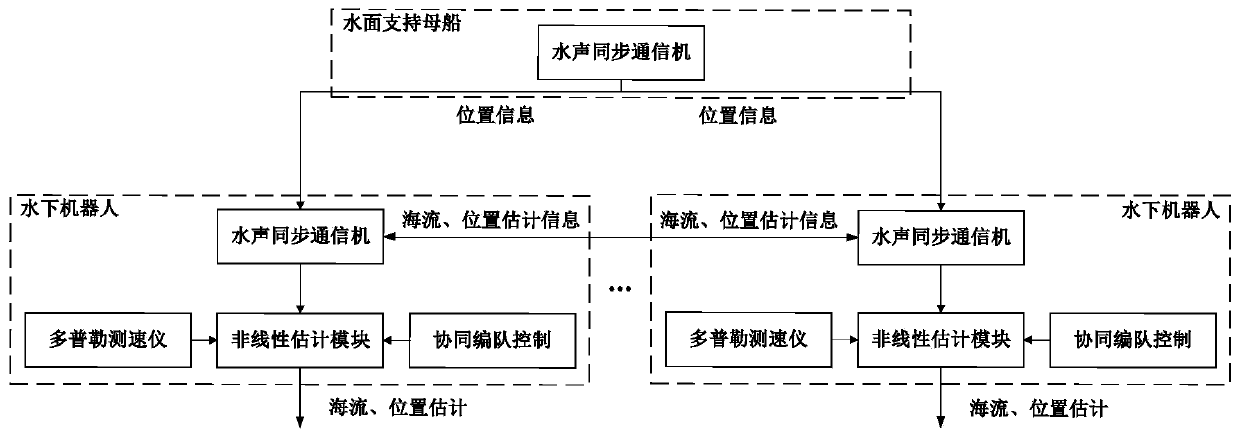
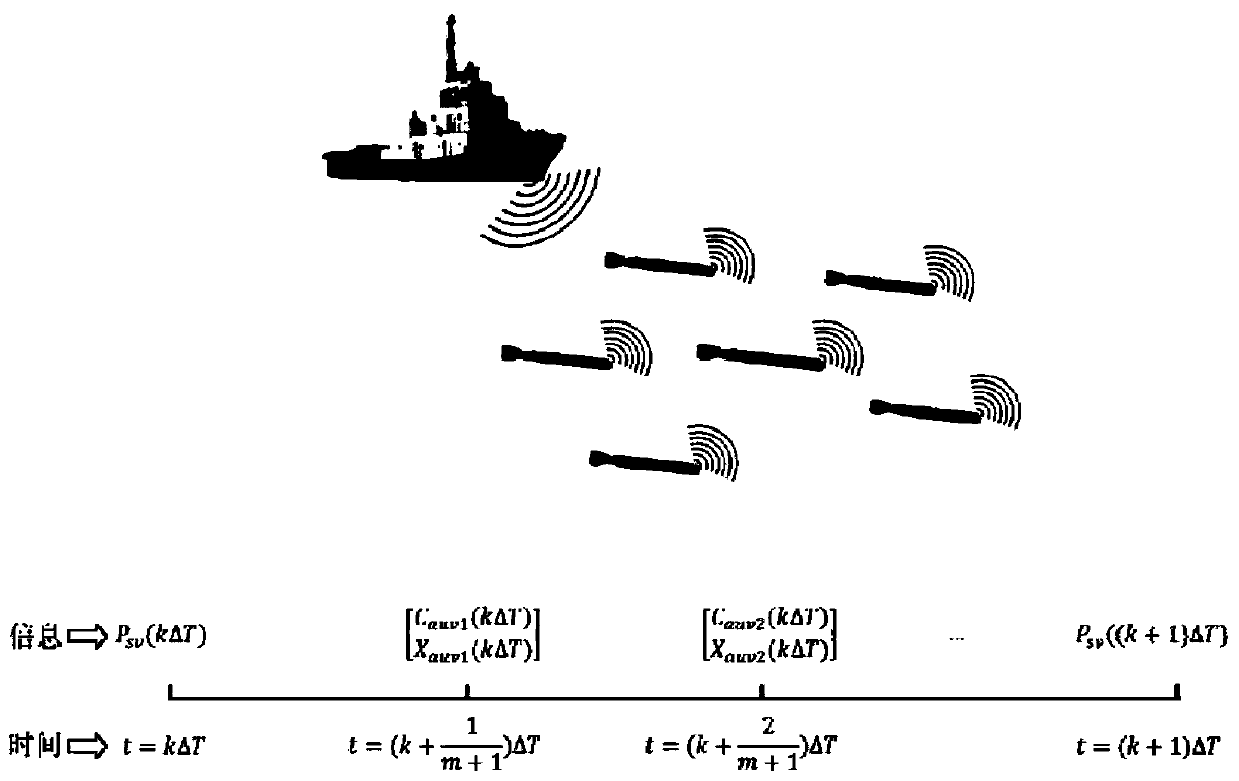
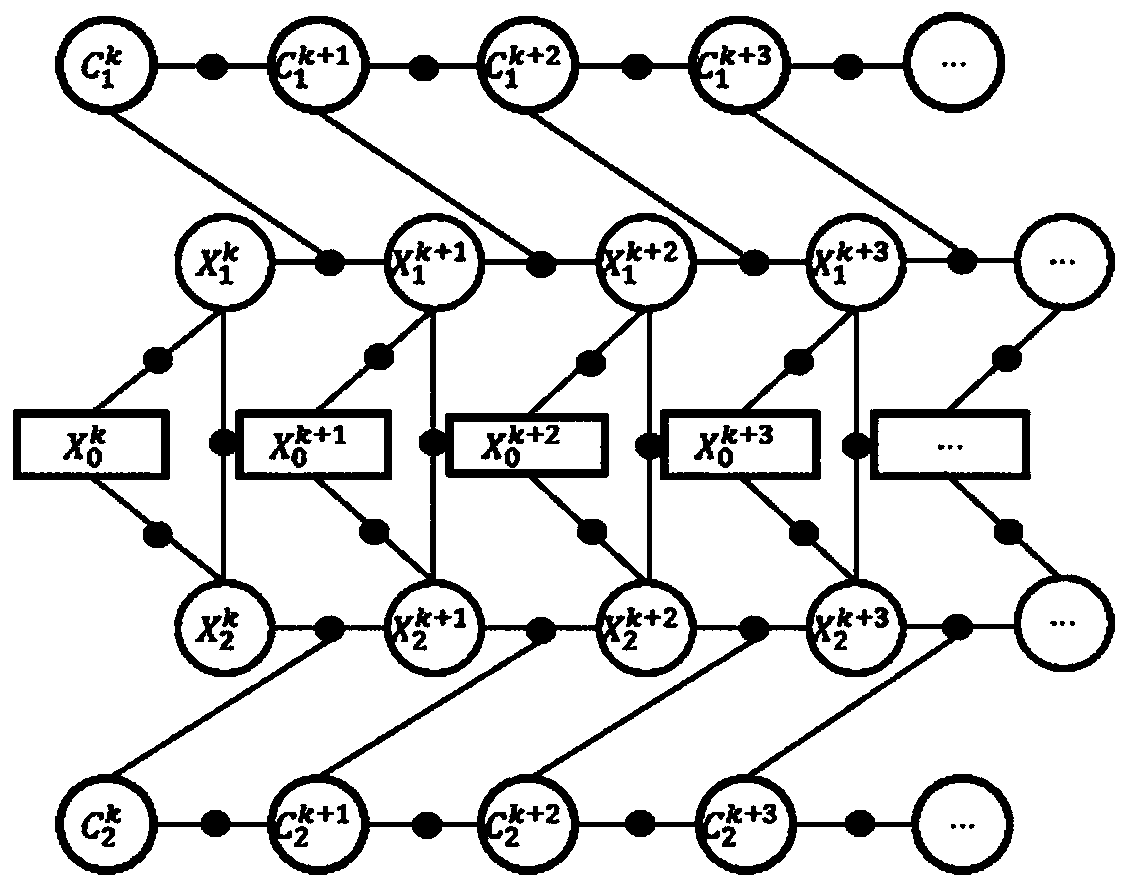
The invention relates to a multi-underwater-robot cooperative ocean current estimation method. The method comprises the following steps of: starting a Doppler velocimeter, an underwater acoustic synchronous communication machine, a nonlinear estimation module and a cooperative formation control module; when an information state is bottom-to-bottom speed measurement, broadcasting position information by an underwater robot to achieve cooperative formation navigation operation; when the information state is convection speed measurement, entering an estimation discriminator to determine whether ocean current estimation needs to be carried out or not; achieving ocean current estimation by the nonlinear estimation module according to the position of a water surface supporting a mother ship, distance information, position estimation information, ocean current estimation information and distance information with other underwater robot; and fusing the ocean current estimation result and Doppler speed measurement information to compensate the position errors to the flow velocity measurement brought by the Doppler velocimeter to achieve position estimation of the underwater robot. The navigation capacity of the multi-underwater-robot system in the deep sea area can be improved, long-time deep sea area navigation without water outflow is achieved, and the large-range navigation requirement and the operation efficiency requirement are met.
Owner:HARBIN ENG UNIV
Three-channel water surface composite yacht
InactiveCN106184640AOptimize layoutImproved heading stabilityHull partsHydrodynamic/hydrostatic featuresEngineeringMarine navigation
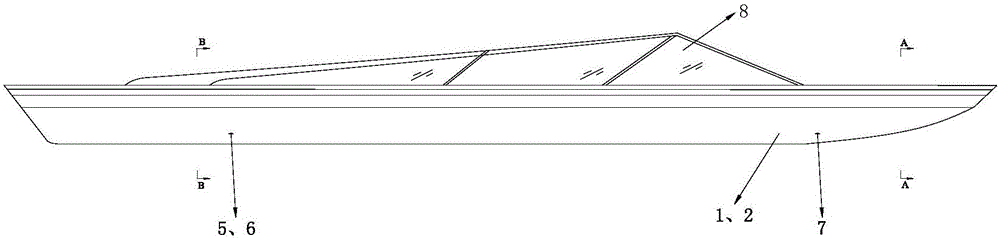
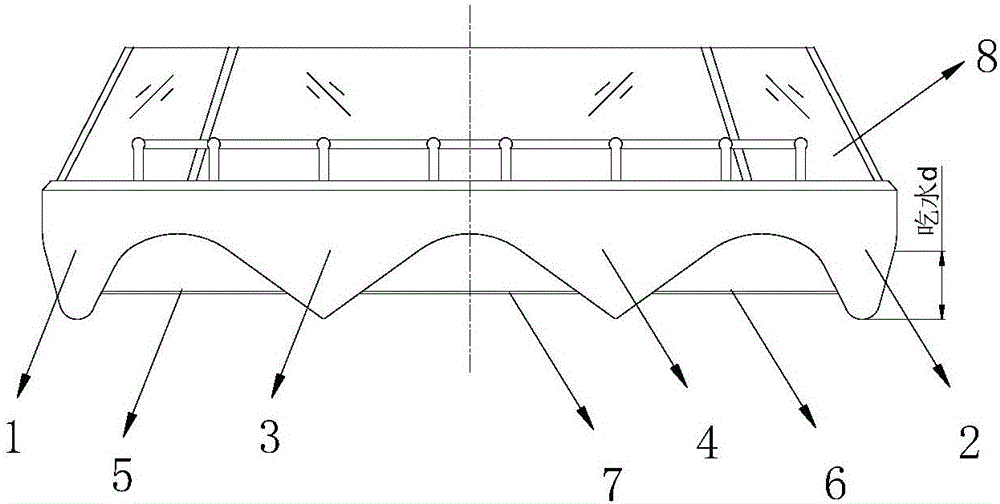
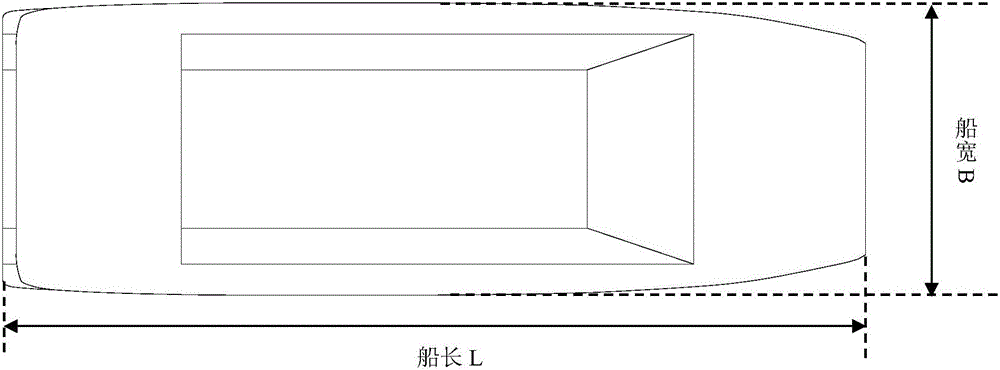
The invention discloses a three-channel water surface composite yacht which comprises a main yacht body. Side bodies are arranged on the two sides of the bottom of the main yacht body respectively. Two middle yacht bodies are arranged between the two side bodies. Three channels are formed between the two side bodies and the two middle yacht bodies. Hydrofoil systems are arranged at the front ends or the rear ends of the three channels. Each hydrofoil system comprises a hydrofoil, a rotating rod and a control device, wherein the rotating rod penetrates through the hydrofoil, the rotating rod drives the hydrofoil to rotate, the control device is installed on the corresponding middle yacht body and connected with the hydrofoil through the rotating rod, and the hydrofoil is driven by the control device to rotate. According to the three-channel water surface composite yacht, through the combination of the good layout characteristic, good resistance performance and high shipping-direction stability of a three-channel skimming yacht and the rapidness and good comprehensive navigation performance of a hydrofoil yacht with controllable hydrofoils, the inherent defects of the three-channel skimming yacht and the hydrofoil yacht are well overcome.
Owner:JIANGSU UNIV OF SCI & TECH
Retractable apron structure of amphibious aircraft
PendingCN109733376AImprove sailing performanceHigh structural responsivenessAir-cushionAircraft convertible vehiclesJet aeroplaneSeakeeping
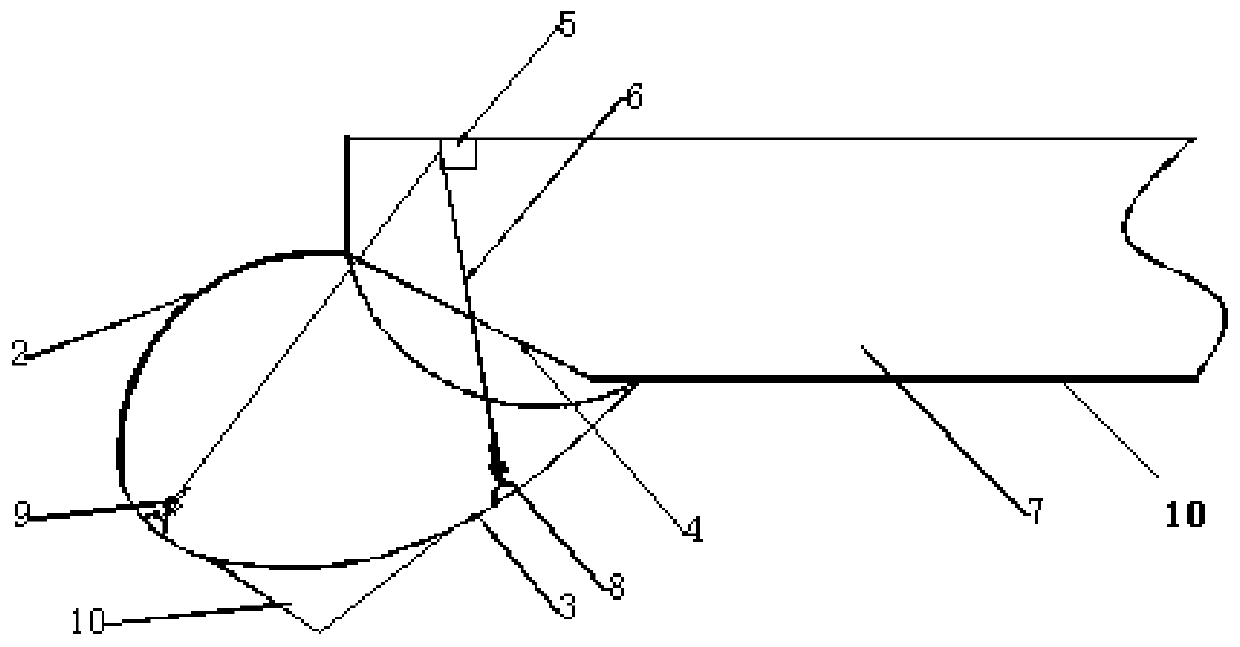
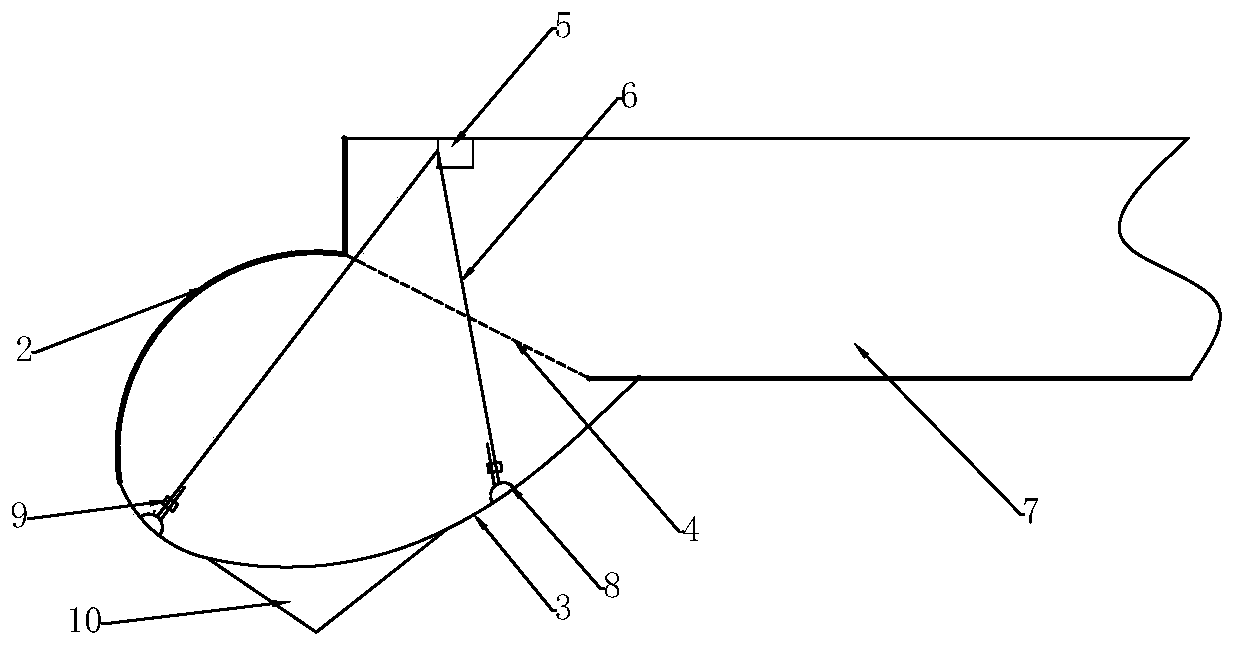
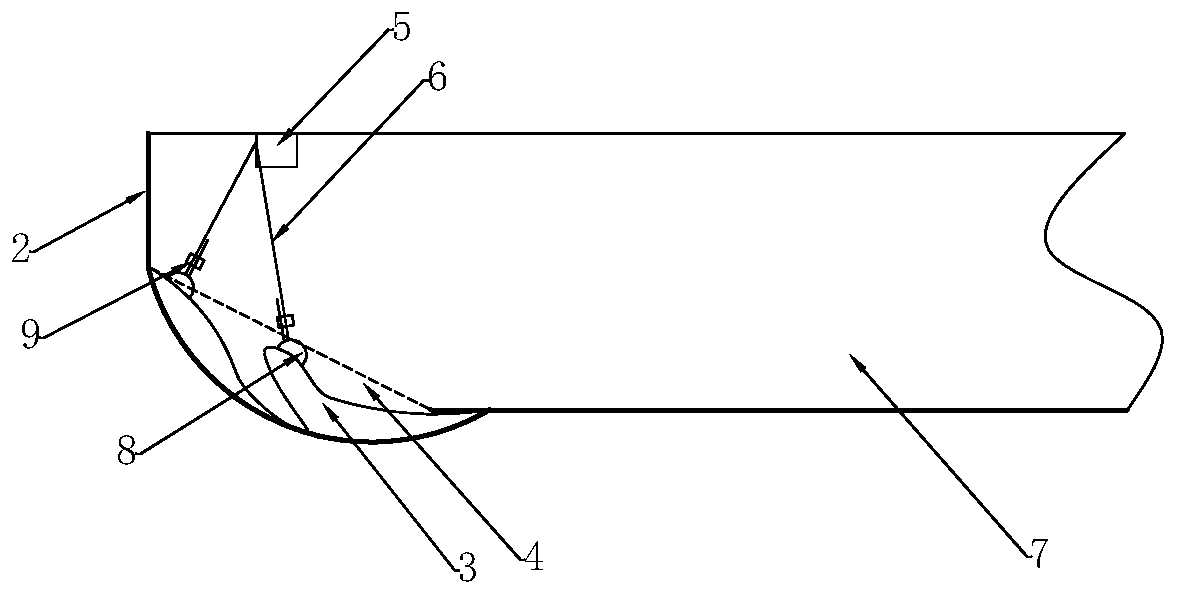
The invention provides a retractable apron structure of an amphibious aircraft. The retractable apron structure comprises an apron structure and a capsule body retracting device. The apron structure comprises an arc-shaped rigid surface and a capsule body, wherein one end of the arc-shaped rigid surface is hinged to a hull, the other end of the arc-shaped rigid surface is hinged to the capsule body, the capsule body is further hinged to the bottom of the hull, and an exhaust hole channel is arranged at the joint between the capsule body and an air chamber. The capsule body retracting device comprises a connecting rope, a miniature electric hoist and a connecting piece, wherein the miniature electric hoist is arranged at the top end of the air chamber, the connecting piece is arranged on the capsule body, the connecting piece is connected to one end of the connecting rope, and the miniature electric hoist is connected to the other end of the connecting rope. The retractable apron structure of the amphibious aircraft is simple in structure, easy to operate and convenient to inspect and maintain, and can well adapt to two working conditions of an air cushion aircraft, the response ofthe apron structure is higher during sailing at sea, and the seakeeping is good; and the retractable apron design can reduce the flying resistance during flying, and the air cushion aircraft is enabled to have better navigation performance.
Owner:HARBIN ENG UNIV +2
Crosswise double-strut supporting type superstructure of unmanned surface vehicle
InactiveCN103612716AImprove anti-overturn performanceImprove unsinkabilityVessel superstructuresVessel mastsUpper floorSuperstructure
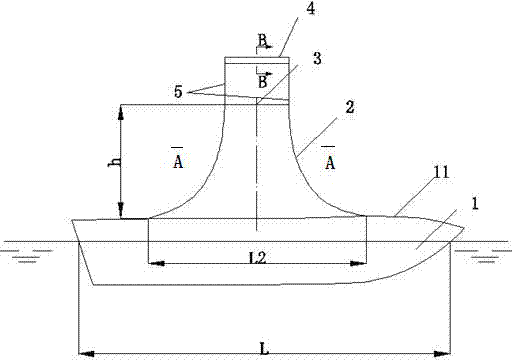
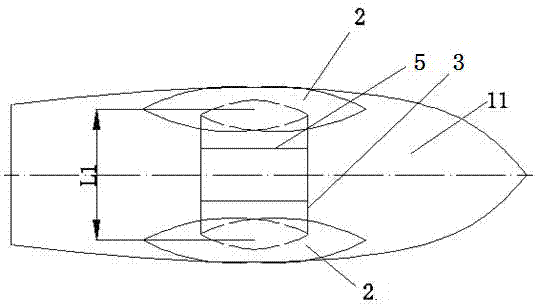
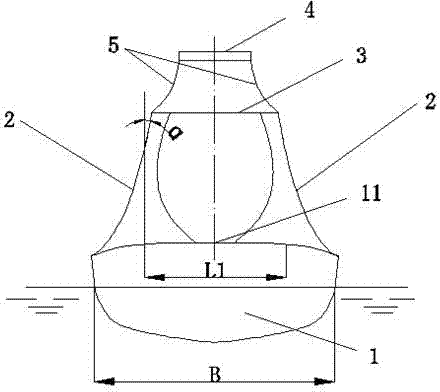
The invention discloses a crosswise double-column supporting type superstructure of an unmanned surface vehicle. Two fully-closed struts are symmetrically arranged on a deck of a main vehicle body in the left-and-right width direction, the center of the two struts is located on the midship portion or at the position which is located in front of the midship by (1 / 8-1 / 6) L, L is the designed waterline length of the main vehicle body, the contour line between the front-most edge of the each strut and the rear-most edge of the strut from top to bottom is a quadratic parabola, and the area of the horizontal cross sections of the two struts decreases gradually from top to bottom. A first-layer perception platform and a second-layer perception platform located over the first perception platform are arranged at the top of each strut, and the first-layer perception platforms are connected with the second-layer perception platforms through connecting columns to form a composite framework of the perception platforms. Thus, perception equipment can be better arranged, the longitudinal stability of sailing of the vehicle body can be enhanced, and the sailing performance and the self-righting performance of the unmanned surface vehicle during wave sailing are enhanced.
Owner:JIANGSU UNIV OF SCI & TECH
Ship navigation performance optimization method and system considering uncertainty variables
PendingCN119262236AImprove sailing performancereduce fuel consumptionWaterborne vesselsClassical mechanicsControl theory
The invention provides a ship navigation performance optimization method and system considering uncertain variables, and the method comprises the steps: calculating ship oil consumption and ship energy efficiency operation indexes based on obtained ship operation parameters and port parameters, calculating an actual navigation speed value interval through employing a 3sigma criterion, taking the actual navigation speed value interval as a constraint condition, and carrying out the optimization of the ship navigation performance. Establishing a target function based on a preset weight coefficient, the ship oil consumption and the ship energy efficiency operation index; the method comprises the following steps: setting navigation intervals and weather intervals based on a time dimension, further calculating a weather array corresponding to each navigation interval by adopting a specific calculation method, and then setting an initial actual navigation speed of a certain navigation interval in an actual navigation speed value interval; and taking the initial actual navigational speed and the weather array corresponding to the navigation interval as the initial solution of the simulated annealing algorithm, and finally calculating the optimal navigational speed of each navigation interval by adopting the simulated annealing algorithm, thereby realizing the optimization of the ship navigation performance and effectively improving the ship navigation performance.

Owner:SHANGHAI SHIP & SHIPPING RES INST CO LTD +1
Buoyancy tank self-lubricating type four-drive working vehicle
ActiveCN112976971AWith a variety of job functionsReduce wearAmphibious vehiclesWaterborne vesselsMarine engineeringHydraulic ram
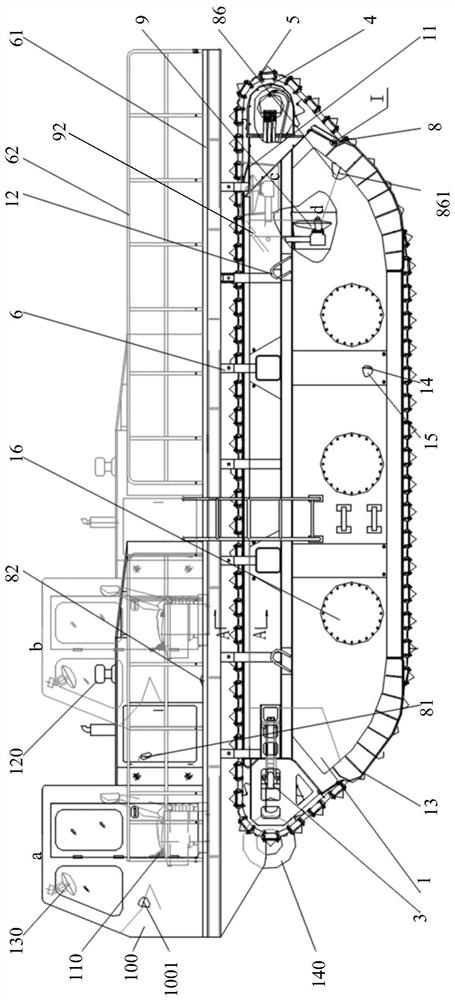
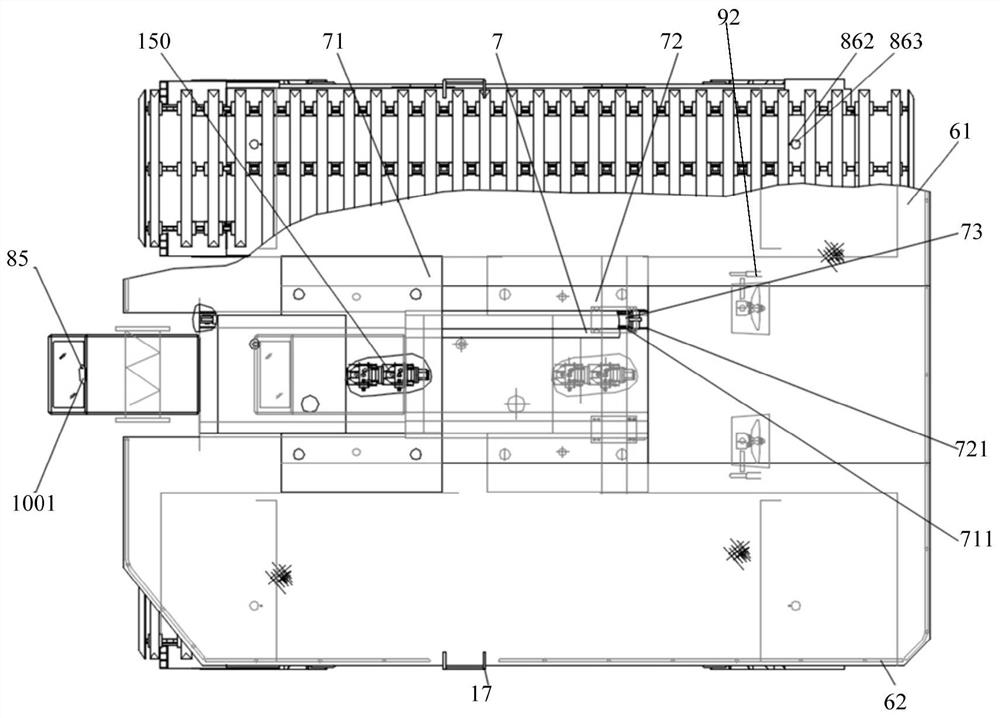
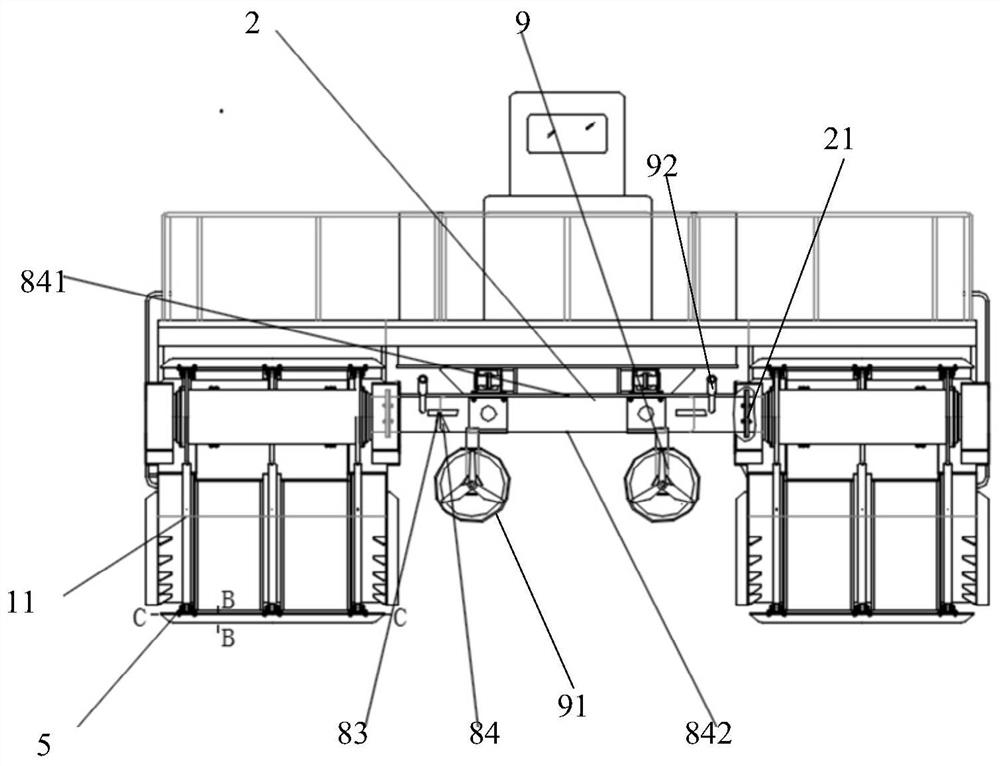
The invention provides a buoyancy tank self-lubricating type four-drive working vehicle which comprises a double-body buoyancy tank structure provided with a track, a working platform and a movable platform, wherein a guide mechanism is installed at the front end of the double-body buoyancy tank structure, a drive mechanism is installed at the rear end of the double-body buoyancy tank structure, and a crawler mechanism surrounds the track, the guide mechanism and the driving mechanism; the working platform is mounted on the double-body buoyancy tank structure; the movable platform comprises a sliding platform and a fixed platform, the fixed platform is fixedly connected to the connecting body through a support and a bracket, a concave slide way is arranged on the fixed platform, a convex slide way matched with the concave slide way is arranged below the slide way platform, and the convex slide way is embedded into the concave slide way; one end of a first hydraulic oil cylinder is internally fixed with the hydraulic oil cylinder hole of the convex slide way through a shaft, the other end of the first hydraulic oil cylinder is internally fixed with the hydraulic oil cylinder hole of the concave slide way through a shaft, and the first hydraulic oil cylinder drives the sliding platform to move. According to the technical scheme, the vehicle is reasonable in structure, large in driving force, reliable and safe in work, high in efficiency, good in applicability and capable of achieving amphibious operation.
Owner:山东野牛机械科技有限公司
Intelligent control system and method for navigational speed and navigational direction of surface ship
PendingCN119596939Aimprove performanceImprove navigation safetyVehicle position/course/altitude controlPosition/direction controlControl engineeringData harvesting
The invention discloses an intelligent control system and method for the navigational speed and the navigational course of a surface ship, and relates to the technical field of ship navigation control, and the system comprises a data collection and mode construction unit, an integrated processing unit, a navigational speed and navigational course control mode selection unit and a real-time monitoring and optimization unit. The data collection and mode construction unit is used for collecting historical navigation data of a surface ship under different sea conditions, constructing a navigational speed and course control mode taking the sea condition data as parameters, and setting each threshold index in the navigational speed and course control mode; and the integrated processing unit is used for carrying out integrated processing on the set navigational speed and course control mode, the threshold value index and a naval vessel controller. By collecting and analyzing the historical navigation data, the navigation speed and course control mode taking the sea condition data as the parameters is constructed, so that the naval vessel can automatically select the optimal navigation mode and parameters according to the real-time sea condition and task requirements, intelligent navigation decision is realized, and the overall efficiency of the naval vessel is improved.

Owner:中国人民解放军91404部队第310所
Ship
InactiveCN111936381AReduce resistanceImprove sailing performanceHull interior subdivisionWatercraft hull designMarine engineeringIce formation
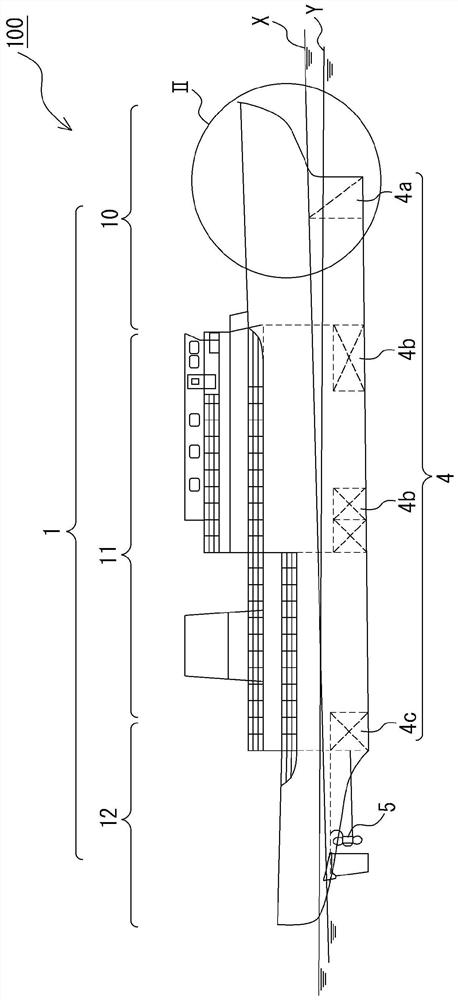
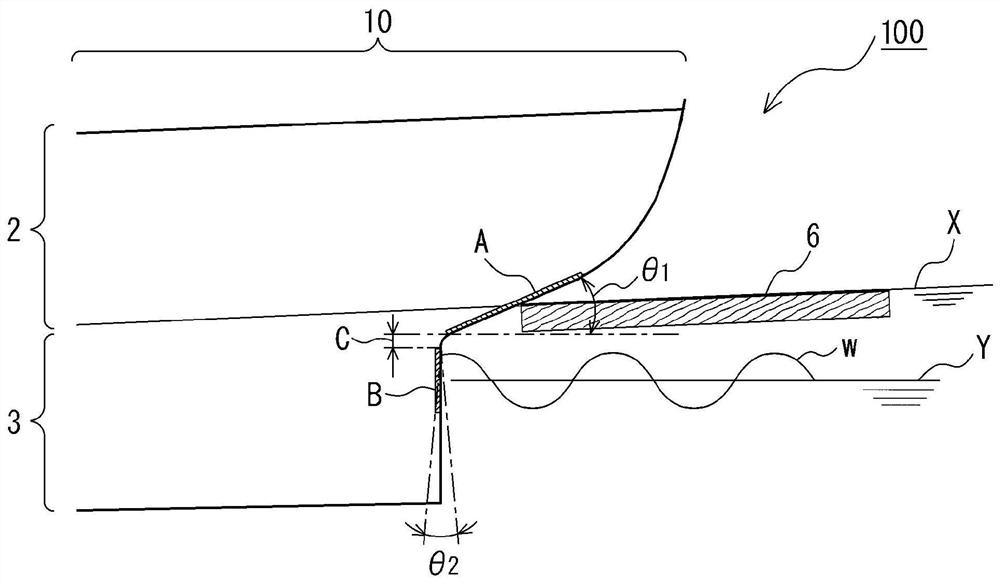
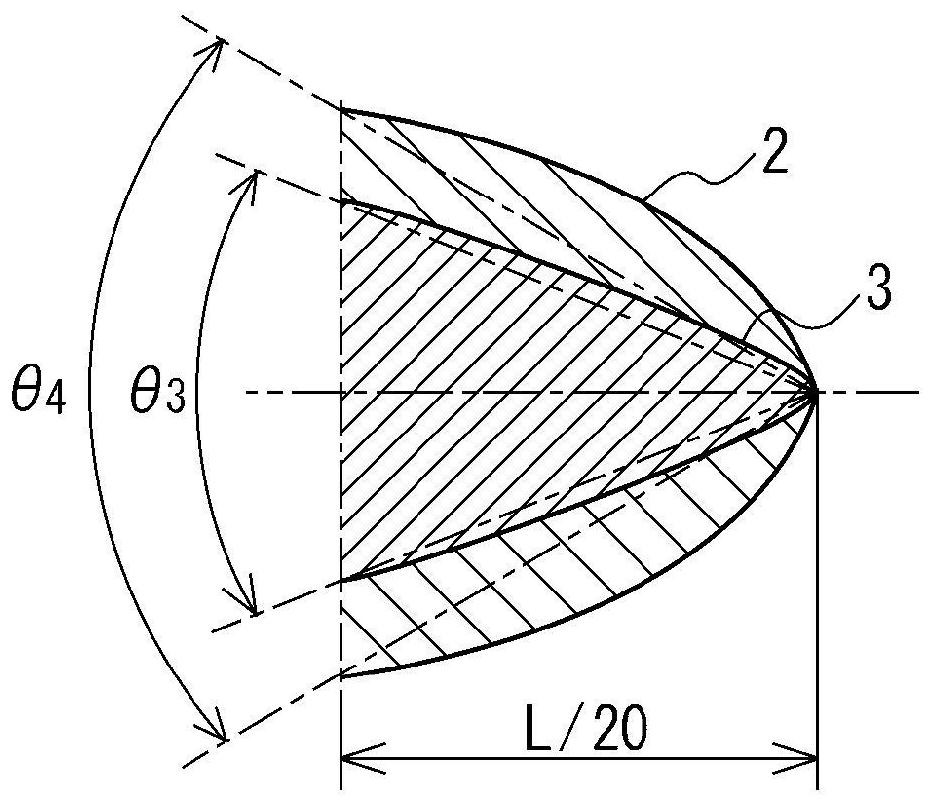
Owner:JAPAN MARINE UNITED CORP
A quasi-ellipsoidal bulbous bow and its design method
ActiveCN115432106BImprove sailing performancesimple designWatercraft hull designHydrodynamic/hydrostatic featuresMechanical engineeringNavigability
The present invention relates to an ellipsoid-like bulbous bow and a design method thereof. The bulbous bow extends from the #0 station toward the bow of a ship, and has a shape similar to an ellipsoid. The cross-section of the bulbous bow is elliptical, and the cross-section gradually decreases from the #0 station toward the bow of the ship; the length of the bulbous bow extending forward from the #0 station is 3% to 5% of the designed waterline length; the half-width of the bulbous bow #0 station is 12% to 18% of the half-width of the hull; and the distance between the bulbous bow #0 station and the water surface is 15% to 20% of the designed draft. The quasi-ellipsoidal bulbous bow proposed in the present invention adopts relatively simple characteristic parameters to describe the shape of the bulbous bow, and the design and construction process are relatively simple; the quasi-ellipsoidal bulbous bow can generally reduce the drag by at least 3% compared with the scheme without the bulbous bow in the cruising state, and can reduce the drag by more than 5% compared with the scheme without the bulbous bow in the design state, so it can be used to improve the navigation performance of the ship, and has important reference and reference value for the design of the bulbous bow of the ship.

Owner:CHINA SHIP DEV & DESIGN CENT
Automatic fixed-point delivery type dual-power yacht and using method thereof
PendingCN114771776ACompact structureEasy to operateLife-raftsAir-sea rescue devicesElectric driveAutomatic control
The invention relates to an automatic fixed-point delivery type dual-power yacht and a using method thereof.The automatic fixed-point delivery type dual-power yacht comprises a yacht body, a transverse wind power mechanism is installed at the front end of a deck of the yacht body, a longitudinal wind power mechanism is installed at the rear end of the deck, and the transverse wind power mechanism and the longitudinal wind power mechanism are both electrically connected with a battery in the yacht body to jointly form an electric driving device; a chain connected with the parachute is arranged in the middle of the top surface of the yacht body; a manual and automatic control system is mounted on the speedboat body between the cable chain and the transverse wind power mechanism; a navigation and environment measurement system is further installed in the yacht body, and a fuel oil power device is rotationally installed on the lower portion of the tail end of the yacht body. The electric driving device and the fuel oil power device jointly form dual power of the speed boat, the electric driving device corrects a delivery fixed point in the descending process of the parachute, and the speed boat is driven by the dual power in a matched mode after the parachute descends, so that automatic fixed-point delivery of the speed boat is achieved, and rescue actions in a severe environment are greatly assisted.
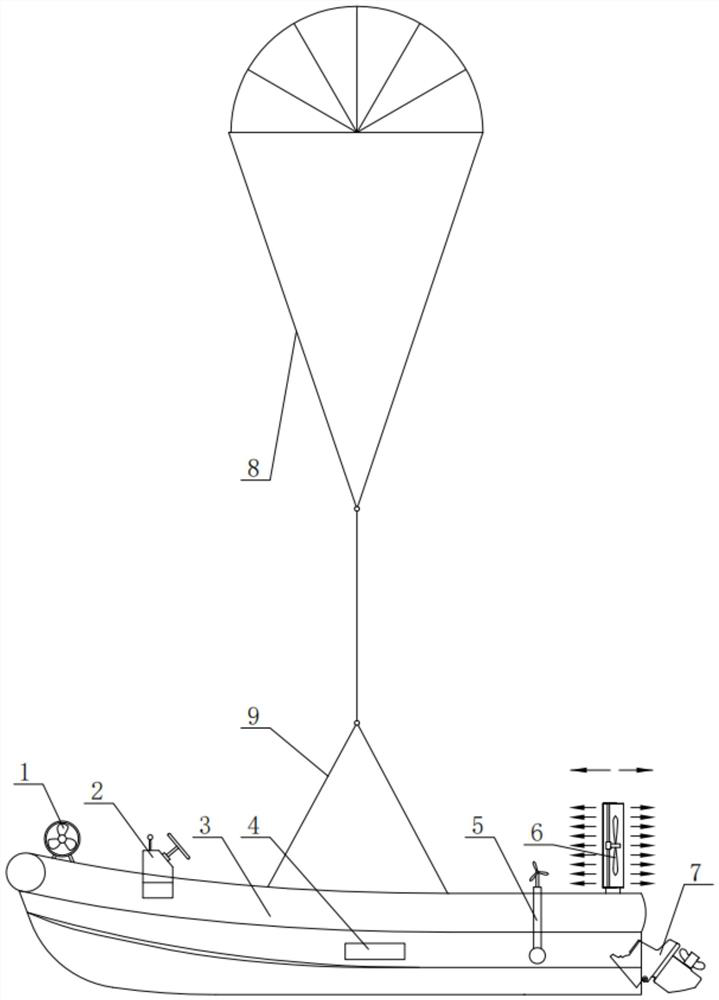
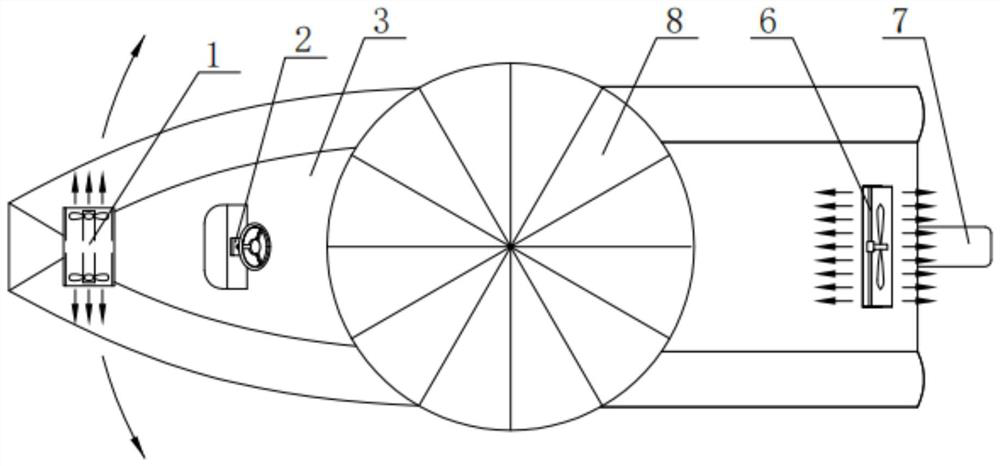
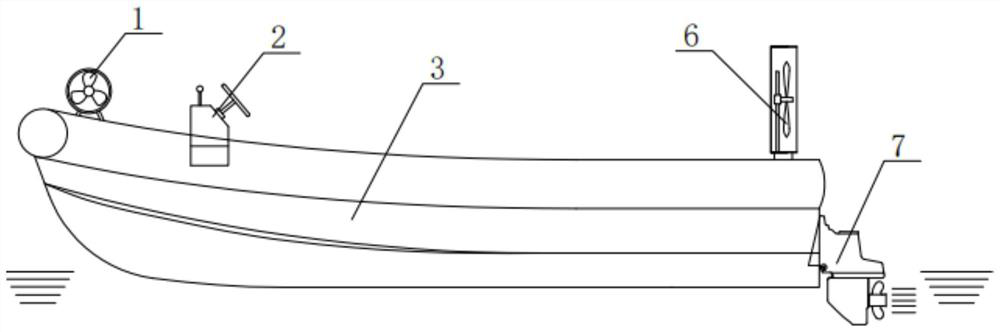
Owner:CHINA SHIP SCIENTIFIC RESEARCH CENTER (THE 702 INSTITUTE OF CHINA SHIPBUILDING INDUSTRY CORPORATION)
Transverse twin-pillar-supported superstructure for unmanned surface vehicles
InactiveCN103612716BImprove anti-overturn performanceIncreased longitudinal stabilityVessel superstructuresVessel mastsMarine engineeringUpper floor
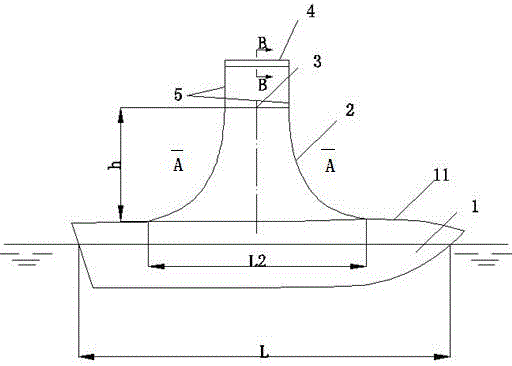
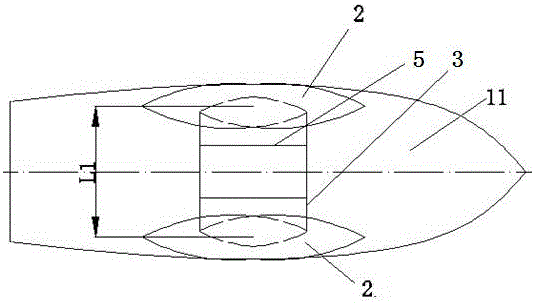
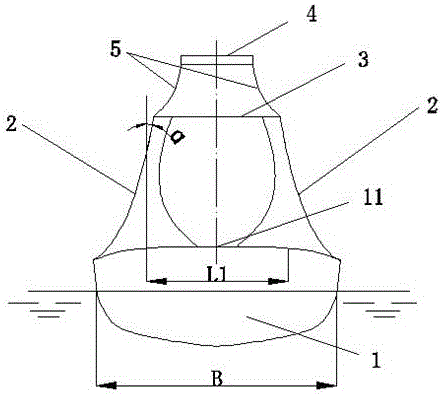
Owner:JIANGSU UNIV OF SCI & TECH
A wing-changing mechanism of an underwater glider
ActiveCN105460187BReduce loadImprove sailing performanceUnderwater vesselsUnderwater equipmentUnderwater gliderFixed wing
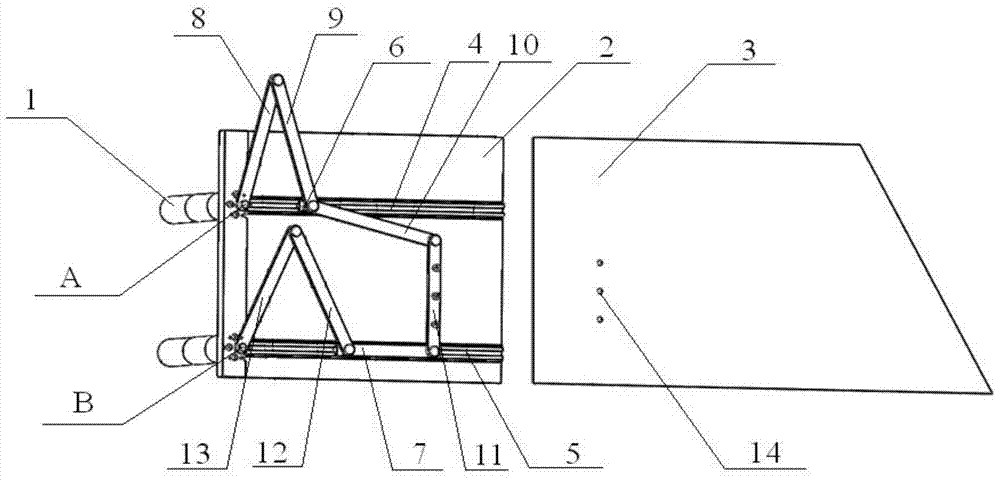
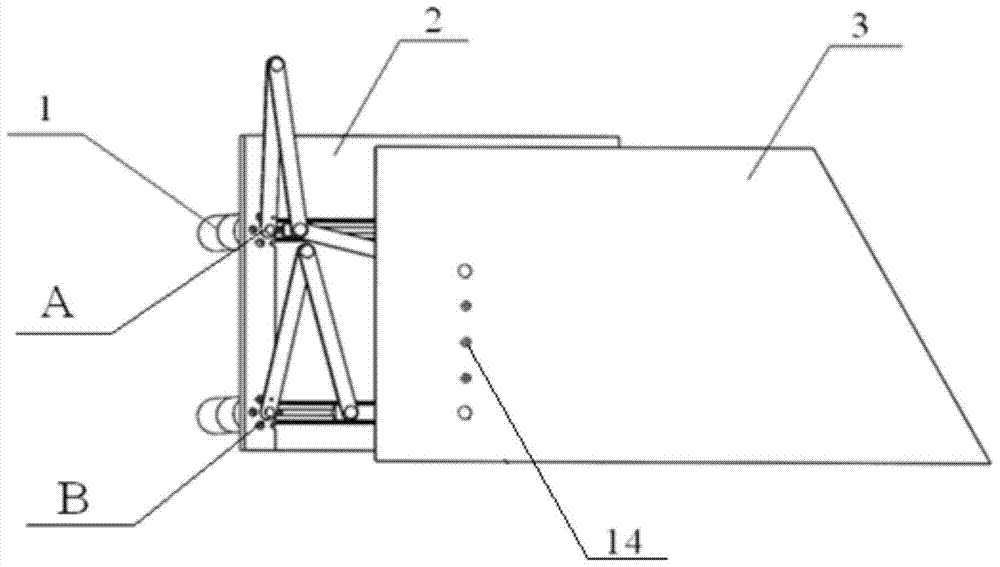
Owner:TIANJIN UNIV
Marine empennage
InactiveCN119659835AIncrease the bearing areaImprove lateral stabilityWatercraft hull designHydrodynamic/hydrostatic featuresWater flowMechanical engineering
The invention discloses a marine empennage, which relates to the technical field of ships, and comprises a ship shell of a wave-shaped flat bottom structure, and the upper end of the ship shell is fixedly connected with a deck used for covering the space in a ship and horizontally dividing the space into layers; the side, close to a deck, of the hull is fixedly connected with a cabin used for storing materials and allowing sailors to work and live, the outer wall of the side, away from the cabin, of the hull is fixedly connected with an empennage plate body used for keeping course stability and providing rotation or trim adjusting capacity, and dynamic wingspan expansion mechanisms are arranged on the two sides of the upper end of the empennage plate body. An arc wing guide swing mechanism is arranged at the center of the upper end of the empennage plate body, a trapping screen wing mechanism is arranged on one side of the tail end of the empennage plate body, plate wings and an electric telescopic rod are matched with each other, and the stress area of the empennage can be increased by improving the sailing performance and expanding the wingspan; therefore, larger lift force is generated under the condition of the same wind speed or water flow.

Owner:NANTONG HAIGUO MACHINERY
Ship heel balance automatic control system and method
ActiveCN104229092BImprove the anti-shake effectGood sailing attitudeVessel movement reduction by mass displacementMovement controllersAutomatic controlControl system
The invention provides an automatic control system and an automatic control method for ship heeling balance. Multiple anti-heeling pumps capable of independently working and multiple pairs of anti-heeling ballast tanks are arranged in the automatic control system, so that rolling of a ship in a moored condition, at various navigational speeds, such as a medium-high navigational speed, a low navigational speed and a zero navigational speed and under various encounter wave directions can be effectively reduced, and heeling and trimming caused to the ship by various factors: loading unbalance, local cabin breakage and wind pressure, are rapidly compensated, so that special engineering ships like pipe-laying ships and the like have low economic risk, can adapt to severe environment conditions, and meanwhile, have the characteristics of operational safety of offshore working, and the like. The automatic control system and the automatic control method for the ship heeling balance have very good popularization and use value.
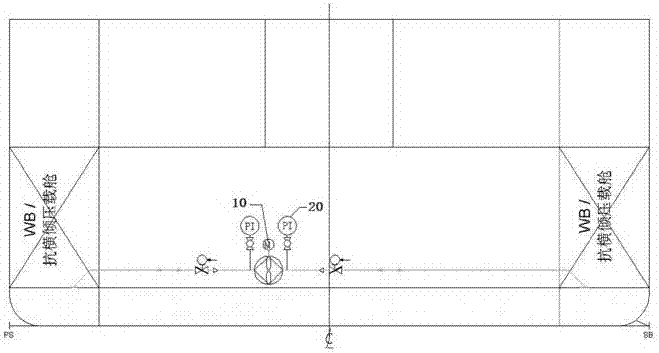
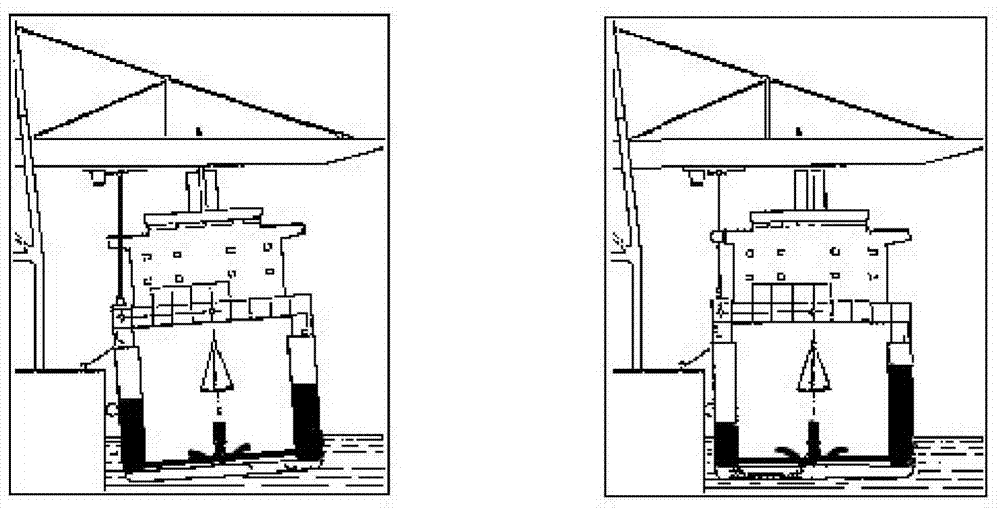
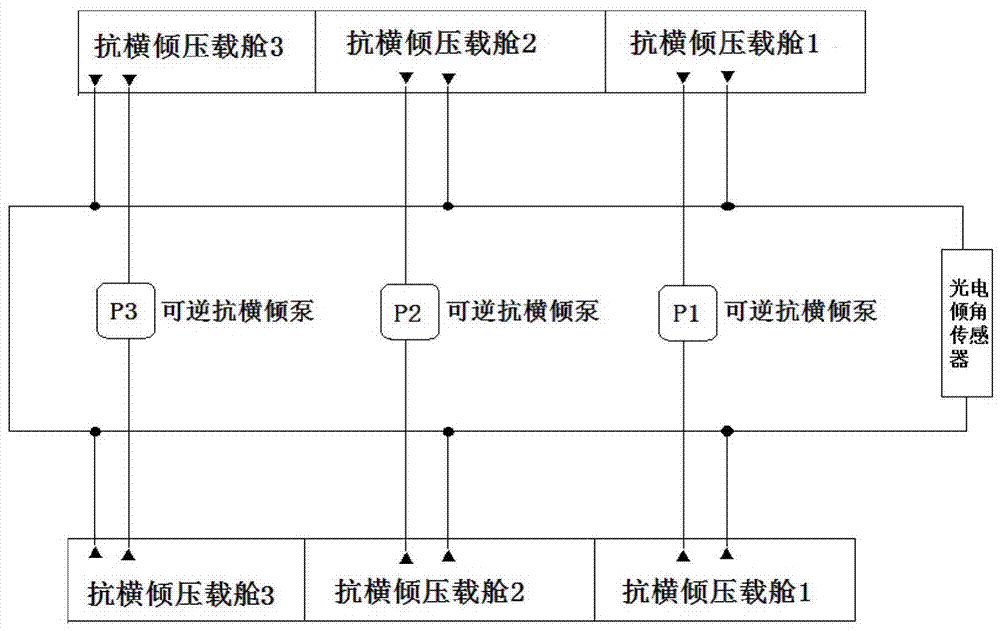
Owner:COSCO SHIPPING SHIPYARD (NANGTONG) CO LTD +1
Anti-rolling tank control device
ActiveCN101624087BIncrease the effective cross-sectional areaReduce the effective cross-sectional areaVessel movement reduction by mass displacementMarine engineeringControl signal
An anti-rolling water tank control device mainly solves technical problems such as improving ship anti-rolling effect. There is a throttling component on the second channel, the second component is connected to a controller, the controller is connected to a detector, the detected ship swing period signal is input to the controller, and the control signal is output to the second throttling component according to the set rules. The flow assembly adjusts the effective cross-sectional area of the second throttling channel to realize the water level alternation period of the U-shaped anti-rolling tank which is the same as the ship's swaying period, and is suitable for various U-shaped anti-rolling tanks.
Owner:SHANGHAI HUNTER MARINE EQUIP CO LTD