

Patents
Literature
394 results about "Gasoline station" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
A gas station, also known as a filling station, fueling station, service station or petrol station is a facility which sells fuel and lubricants for motor vehicles. The most common fuels sold are gasoline (petrol) or diesel fuel.
Automatic refueling control system based on artificial intelligence
ActiveCN119143069AGuaranteed uptimeImprove operational efficiencyLiquid transferring devicesInformation controlControl system
The invention belongs to the technical field of refueling control, and particularly discloses and provides an automatic refueling control system based on artificial intelligence, which comprises a target vehicle information detection module, a fuel tank cap position identification module, a fuel tank cap opening control module, an insertion posture confirmation module, a refueling confirmation execution module, a database and a refueling completion reset module. Through cooperative work of a plurality of modules, automation of the whole process from vehicle entering a gas station to refueling completion is achieved, efficient, safe and reliable operation of vehicle refueling is ensured, meanwhile, by confirming target insertion posture information of a refueling gun, the refueling gun is controlled to be inserted into a refueling port, and the refueling efficiency is improved. The problem of insufficient attention of preparation control before automatic refueling of the vehicle at present is effectively solved, the influence of the vehicle posture and the influence of the refueling posture are fully considered, fine control over the corresponding posture of the refueling oil gun is achieved, and the stability of the refueling process and the reliability of oil quantity control are guaranteed.

Owner:AEROSPACE CLOUD MASCH (BEIJING) TECH CO LTD
Mobile and Stationed Electrical Vehicles Charging System
InactiveUS20240416781A1Charging stationsElectric vehicle charging technologyDriver/operatorFuel tank
A mobile and stationed charging system for electric cars designed to expand the charging infrastructure instead of the limited charging stations connected to public electricity networks, charging on the power of soundless electric generators to avoid noise, and operating on gasoline, diesel, natural gas, or hydrogen. To protect the environment, palladium is used in the catalytic converter to purify the exhaust gas, and a third level rapid charging device “high power charger” (HPC) is added. Fixed stations are integrated within the scope of traditional gas stations and may share with them the use of one of the fuels. Mostly they are independent. They can be installed and operated anywhere, either mobile stations on conventional or electric self-driving cars or with a driver with sufficient fuel tanks, with communication devices to meet charging requests anywhere. The charging system could be a solution for expanding the charging infrastructure.


Owner:ALOTAIBI MUTLAQ SENHAT Z
Shunting type gas station management method based on Internet of Things
The invention relates to the technical field of gas station management, and discloses a distributed gas station management method based on Internet of Things, which comprises the following steps: collecting real-time data of vehicles in a gas station by using an Internet of Things sensor; calculating the vehicle distribution density according to the collected data; the cloud computing platform is used for analyzing the vehicle data and the vehicle density data, a prediction model of the vehicle flow and the refueling demand is generated, and an operation strategy of the gas station is adjusted; calculating a path from the current position to a specified oiling machine through an optimization algorithm, and guiding the vehicle; real-time navigation and predicted latency information are provided to a driver using a dynamic display screen. Through application of the Internet of Things technology, real-time data collection and processing of the vehicles in the gas station are achieved, the vehicle overstock condition can be quickly responded, the vehicle flow direction and oiling machine use are dynamically adjusted through an optimization algorithm, and the vehicle processing capacity and the service speed of the gas station are remarkably improved.

Owner:SHANDONG 2055 DIGITAL TECH CO LTD
Information display device and information display system
To provide an information display device capable of displaying various information helpful for customers in a gas station, etc., and widely taking approaches such as sales promotion and recommendation to the customers, and an information display system.SOLUTION: An information processing device 1 comprises: a vehicle photographing unit 10 which photographs a vehicle entering a facility; a vehicle number recognition unit 20 which recognizes a vehicle registration number from the image acquired by the vehicle photographing unit 10; a display device storage unit 30 which stores information on vehicle registration numbers and information for customers using the facility; an information display device 40 which can display information provided in the facility; a communication interface unit 50 which enables information transmission and reception with the outside; and a display device control unit 60 which controls ech unit. The display device control unit 60 selects or edits and displays the external provision information provided from an information providing source via the communication interface unit 50 in the information display unit 40 on the basis of information on vehicle registration numbers and information on customers who use the facility.SELECTED DRAWING: Figure 2

Owner:HOMENET CARS
Gas station safety risk assessment method and system
ActiveCN120473029AData processing applicationsMolecular entity identificationEngineeringOptical flow
The invention relates to the technical field of gas station safety risk assessment, in particular to a gas station safety risk assessment method and system. The gas station global infrared image is acquired in real time by deploying the multi-band infrared imaging array, dark current compensation, gain correction and atmospheric transmittance calibration are combined, the oil gas concentration detection precision is remarkably improved, and based on the homography matrix dynamic coordinate alignment technology, the oil gas concentration detection precision is greatly improved by utilizing mark point re-projection error optimization and feature point optical flow tracking. The problem of coordinate drifting caused by thermal deformation is solved, it is ensured that the space positioning error is continuously lower than 2 pixels, and by combining time sequence concentration field construction and a hybrid prediction model, precise deduction of an oil gas concentration field at any moment in the future is achieved, real-time monitoring of a gas station is achieved, and fire blast accidents caused by detection lag are eradicated from the source; the technical problem that potential safety risks are difficult to discover in time through an existing method for monitoring the oil gas concentration of the gas station is solved.

Owner:SHANDONG NUOLAN INFORMATION TECH CO LTD
Tax-related traceability management system and method for product oil sales multi-dimensional evidence chain
The invention discloses a tax-related traceability management system and method for a multi-dimensional evidence chain of oil product sales, and the system comprises an identification module which is used for generating corresponding identification data according to the identification of an intelligent device; acquiring gas station scene information acquired by the intelligent equipment; the gas station scene information carries a corresponding timestamp; the acquisition module is used for acquiring the oiling machine data uploaded by the oiling machine from the cloud; the processing module is used for judging whether to merge the corresponding identification data, gas station scene information and refueling machine data or not on the basis of a preset merging rule so as to form a multi-dimensional evidence chain; wherein the merging rule comprises a time judgment rule; carrying out the final calculation of the merged data according to a preset time period, so as to calculate the corresponding tax-related data; the system has the advantages that the refueling machine data is combined with other external data, and the defect that a comprehensive sales multi-dimensional evidence chain is difficult to form at present is overcome.

Owner:GOLDEN DOUDOU INTERNET CO LTD
On-tank valve
An on-tank valve for fitting to a tank to supply stored gas to a consumer and the tank to be replenished with gas from a filling station. The valve has a valve body defining at least two flow passages in communication with the tank. A first flow passage incorporates a solenoid valve to control the flow of gas from the tank to the consumer and the second incorporates a manually operable bleed valve for stored gas to be supplied to the consumer while bypassing the solenoid valve. The bleed valve is a combination valve movable manually between two states. In the first state stored gas is permitted to flow from the tank to the consumer and in the second state the second passage incorporates a non-return valve to permit the tank to be replenished from the filling station without the replenishment gas passing through the solenoid valve.

Owner:METIER VENTURES LTD
Systems and methods for drive mode control
PendingUS20250222916A1Hybrid vehiclesInstruments for road network navigationCarbon footprintMode control
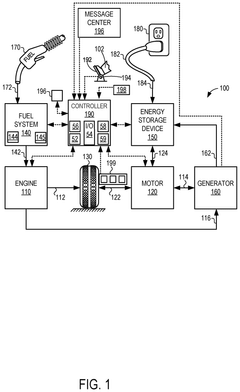
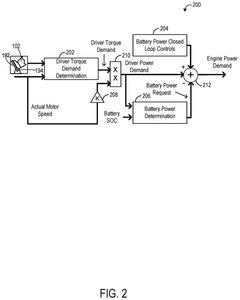
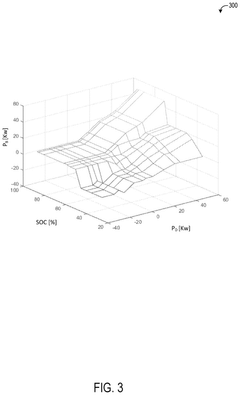
Methods and systems are provided for selectively controlling hybrid drive modes of a hybrid vehicle to reduce emissions. In one example, a method may include using route planning and vehicle operating conditions to identify emissions reducing opportunities. In one example, in response to a route distance not exceeding an electric range, the method includes suppressing an operation of an engine based on the route data, ambient temperature, and cabin pre-conditioning. In response to the route distance exceeding the electric range, further in anticipation of a fuel station along the route, where the fuel station has a fuel with a carbon footprint less than a low carbon threshold, the method includes operating the hybrid vehicle in a charge sustaining or charge increasing mode prior to a refueling event at the fuel station.
Owner:FORD GLOBAL TECH LLC
Methods and internet of things (IOT) systems for maintaining smart gas filling station based on safety supervision
ActiveUS20250117004A1Data processing applicationsRoad vehicles traffic controlReliability engineeringReal-time computing
Disclosed is a method and an IoT system for maintaining a smart gas filling station based on safety supervision. The method comprises: obtaining historical gas filling data; determining, based on the historical gas filling data, a predicted usage feature; obtaining historical operation data; determining a historical operation feature based on the historical operation data; determining an operation and maintenance parameter based on the predicted usage feature and the historical operation feature, and generating a maintenance instruction; obtaining a count of reference vehicles; and generating a regulation instruction in response to determining that the count of the reference vehicles is greater than a reference threshold. The IoT system comprises a government safety supervision service platform, a government safety supervision management platform, a government safety supervision sensor network platform, a government safety supervision object platform, a gas company sensor network platform, and a gas equipment object platform.

Owner:CHENGDU QINCHUAN IOT TECH CO LTD
Utilizing machine learning and transaction data to determine fuel prices at fuel stations
A fuel price determination system may receive transaction data identifying purchases, made with transaction cards and mobile transaction card applications of client devices, of fuel at fuel stations. The fuel price determination system may receive location data identifying locations associated with users of the client devices and the transaction cards, and user history data associated with prior purchases of fuel at fuel stations by the users. The fuel price determination system may process the transaction data, location data, and user history data, with a machine learning model, to determine fuel prices at the fuel stations. The fuel price determination system may determine a ranked list of particular fuel stations in a geographical area based on the fuel prices and populate, based on the location data and the ranked list, a map to identify the particular fuel stations and the fuel prices at the particular fuel stations.

Owner:CAPITAL ONE SERVICES LLC
Monitoring refueling operations
PendingEP4502975A1Payment architectureLiquid transferring devicesMedia serverReliability engineering
A method for detecting fuel fraud when refueling a vehicle at a filling station comprises obtaining, in conjunction with a current refueling operation in which the vehicle is refueled at the filling station, current refueling information (66), determining if there is a mismatch between the obtained current refueling information (66) and historical refueling information (74) which is based on a plurality of past refueling operations in which comparable vehicles were refueled, and raising a potential fraud warning (80) based at least in part on a determined mismatch. The current refueling information comprises at least: first information (70.1) indicating a distance the vehicle (30) traveled since at least a previous refueling operation, second information (70.2) indicating a duration and / or progress of the current refueling operation, and third information (70.3) indicating an amount of fuel dispensed by a fuel pump (12) in the current refueling operation. One or more machine-readable media, a server installation (28) and a system are adapted to perform corresponding operations or cause corresponding operations to be performed.

Owner:RYD GMBH
Apparatus for Mitigating Contamination in Fuel Tanks
An apparatus for mitigating contamination in a fuel supply is an ultrasonic generator coupled with a piezoelectric transducer that propagates ultrasonic waves through a fuel tank. In some embodiments the apparatus is used to mitigate the growth of microbial organisms. In other embodiments the apparatus is used to emulsify water into the fuel, particularly in diesel fuel. The apparatus addresses water and microbial growth found in boats, cars, and aircraft as well as in storage tanks such as those used at fuel stations. In some embodiments, the fluid is diesel fuel.

Owner:LOCCISANO VINCENT
Endurance mileage algorithm for extended-range electric vehicle
The invention relates to the technical field of electric vehicles, in particular to an extended-range electric vehicle endurance mileage algorithm, which comprises the following steps of: S1, aiming at different batteries, obtaining real-time available residual electric quantity Ebatteriaval of the batteries; the method comprises the following steps: S1, starting a VCU (vehicle control unit), S2, after the VCU is initialized, reading data of a previous driving cycle in an EEPROM (electrically erasable programmable read-only memory), and calculating average power consumption data per hundred kilometers and pure electric endurance mileage, S3, carrying out upper and lower limit value processing on the filtered pure electric endurance mileage, S4, calculating oil-electricity comprehensive endurance mileage, S5, carrying out limit value processing on the oil-electricity comprehensive endurance mileage again, and S5, carrying out limit value processing on the oil-electricity comprehensive endurance mileage. The problem that the driving mileage is calculated inaccurately at the present stage, if a driver does not supplement energy in time when a charging pile is far away from a gas station, the vehicle may lie down due to no oil and no electricity, and normal vehicle use of a user is affected is solved.

Owner:ZHEJIANG UFO AUTOMOBILE MFG CO LTD +1
Gas station digital twin system and virtual gas station scene generation method
The invention relates to a gas station digital twinning system and a virtual gas station scene generation method, the system comprises a mapping module and a processing module, the mapping module is used for mapping a pre-constructed scene, an equipment three-dimensional model and a vehicle three-dimensional model to a virtual gas station scene; the processing module is used for processing the equipment operation data to obtain equipment state information, processing the video image to obtain vehicle driving information, and mapping the vehicle driving information and the equipment state information into a virtual gas station scene; acquiring historical refueling data of a gas station, analyzing the historical refueling data, predicting the number of refueled vehicles, the refueling amount, the average refueling time and the fuel amount consumption prediction value in a future time period, and predicting the traffic flow; and performing simulation deduction based on the gas station three-dimensional scene information of the virtual gas station scene to obtain an optimal driving route of the vehicle. The prediction and simulation deduction of the operation condition of the gas station in the future period are realized, and the intelligent level and risk early warning capability of the operation of the gas station are greatly improved.

Owner:RICHFIT INFORMATION TECH +1
Expressway service area service resource allocation method and system based on Internet of Vehicles
PendingCN120343523AParticular environment based servicesIndication of parksing free spacesTraffic congestionParking space
The invention relates to the technical field of expressway service area service resource allocation, in particular to a service area service resource allocation method and system in an expressway scene based on the Internet of Vehicles. Based on wireless communication between the vehicles and the intelligent service area, various service resources such as parking spaces, charging piles / gas stations and rest rooms in the expressway service area can be dynamically managed, the vehicles are distributed to the proper service area through a model algorithm, traffic congestion can be effectively reduced, and the service efficiency is improved. The travel efficiency of the user, the utilization rate of the expressway service area and the economic benefits of various services are improved; by analyzing the spatio-temporal characteristics of the expressway service area, the use scale of various service resources such as parking spaces, charging piles / gas stations and rest rooms in the service area is reasonably measured and calculated, and the service area guiding system is optimally designed, so that various service resource demands in the service area can be accurately identified, the service level of the service area is improved, and the service efficiency is improved. And the construction of an intelligent high-speed service area is promoted.

Owner:DONGFENG MOTOR GRP
Intelligent gas station management system and method based on AI Internet of Things
InactiveCN119299490AImprove user experienceImprove adhesionDigital data information retrievalCharacter and pattern recognitionPersonalizationEmergency plan
The invention relates to the technical field of intelligent gas station management, in particular to an intelligent gas station management system and method based on the AI Internet of Things. Firstly, the running state of key equipment is real-time through Internet of Things equipment, potential safety hazards are recognized, timely processing is carried out through an emergency plan, and in the refueling process, the system can automatically recognize a vehicle, obtain user data associated with the vehicle and generate temporary information credentials for the vehicle; according to the method and the system, the user data is ensured not to be out of order in system data transmission with relatively high concurrency, then the oil product is intelligently recommended, the use experience of a customer is greatly improved, and the system analyzes the consumption data of the user and performs personalized oil product recommendation and preferential pushing, so that the user stickiness is improved. By combining AI and Internet of Things technologies, the intelligent gas station management system can realize equipment real-time monitoring, oil fee payment and safety emergency response, so that the operation efficiency of the intelligent gas station is improved.

Owner:JIANGSU YUNPENG INFORMATION TECH CO LTD
METHOD AND ELECTRONIC CONTROL UNIT (ECU) FOR REFUELLING A VEHICLE
PendingDE102024133359A1Registering/indicating working of vehiclesLiquid transferring devicesFuel tankFuel type
The present disclosure relates to a method for refueling a vehicle (102). The method comprises determining the vehicle (102) approaching a gas station based on location data of the vehicle (102). The method further comprises activating a side detection unit (106) of the vehicle (102) when the vehicle (102) is within a predefined proximity to a fuel pump (108) in the gas station. The method further comprises scanning a Quick Response (QR) code (112) located on a fuel nozzle (110) connected to the fuel pump (108) using the side detection unit (106) to obtain a fuel type associated with the fuel nozzle (110). Thereafter, the method comprises controlling a fuel door connected to the vehicle (102) to refuel the vehicle (102) by comparing the obtained fuel type and a predefined fuel type of the vehicle (102).


Owner:MERCEDES BENZ GROUP AG
System and method to process transactions at retail fueling stations using a mobile device
ActiveUS20250029441A1Payment architectureApparatus for dispensing fluids/granular materialsFinancial transactionMobile device
A method of processing a transaction includes receiving a site location code. Site configuration information corresponding to the received site location code is received from a database. That information includes more product record(s), each corresponding to a reservable product or a non-reservable product. A selection of one or more of the product records in the retrieved information is received. If any selected product record corresponds to a reservable product, a reservation command is produced. That command requests reservation of selected reservable product(s). A method of selecting a product includes receiving a location input and determining a site location code with it. The site location code is transmitted and one or more product records are received. Representations of one or more of the received product records are presented and a selection of products is received. An indication of the selection is transmitted.


Owner:WAYNE FUELING SYSTEMS LLC
System and method for improved fuel dispenser audit compliance
A system for determining fuel dispenser metrological compliance at multiple fueling sites each having a plurality of fuel dispensers. The system comprises a cloud-based computing resource in operative communication with the fueling sites. The cloud-based computing resource is operative to receive a compliance request from a compliance entity for metrological information from a selected fuel dispenser, validate the compliance request, and provide compliance data to the compliance entity.

Owner:GILBARCO INC
Power boosting type diesel oil additive as well as preparation method and application thereof
The invention belongs to the technical field of automotive diesel additives, and particularly relates to a power boosting type diesel additive as well as a preparation method and application thereof. The additive contains 10-30 g / L of an organic lanthanum peroxide component in terms of La, and is a solution prepared from lanthanum carbonate or lanthanum oxide, acetylacetone, hydrogen peroxide and an inert and hydrophobic hydrocarbon solvent; in the preparation raw materials, the molar ratio of La to acetylacetone to H2O2 is 1: (3.0-3.2): (3.3-3.5); the hydrocarbon solvent is composed of a solvent A and a solvent B, the normal-pressure boiling point of the solvent A is 75-100 DEG C and accounts for 20-40 wt% of the total amount of the hydrocarbon solvent, and the normal-pressure distillation range of the solvent B is 70-300 DEG C. The additive is suitable for being added into vehicle diesel oil of a gas station, the adding amount is 0.05-2 v per thousand, the power performance of a diesel oil vehicle can be remarkably improved, and the additive has a certain application prospect.
Owner:DAQIU NEW MATERIALS (SHANDONG) CO LTD
Soil remediation device and method
ActiveCN111515237BImprove repair effectquick fixContaminated soil reclamationWell drillingEnvironmental engineering
The present invention discloses a soil remediation device and method, the device includes a volatile gas capture device, a gas extraction device and an exhaust gas treatment device; the volatile gas capture device is composed of a plurality of horizontal remediation pipes; the method includes a pollution situation survey; forming a remediation protective layer; digging a vertically downward longitudinal side well inside a gas station site away from a traffic road; laying out the horizontal well points, and using the side well as the starting point of drilling, to build a horizontal well toward the pollution source area of the gas station site; turning on the heating resistor rod and the gas extraction device to collect volatile organic pollutants in the horizontal remediation pipe. The method of the present invention can achieve the remediation of the soil below the ground, enhance the thermal conductivity of the soil, quickly remediate groundwater, and cut off the diffusion of pollutants around, while ensuring the normal use of the gas station on the ground. , thereby improving the overall remediation effect of the gas station.

Owner:ZHEJIANG FORESTRY UNIVERSITY +2
Electronic oil gas recovery oil gun and oil gas recovery method
ActiveCN119591045Areduce inhalationreduce excess emissionsLiquid transferring devicesIn vehicleProcess engineering
The invention provides an electronic oil gas recovery oil gun which comprises a sealing and pressure detection module used for sealing an oil filling port of an injected container and detecting the pressure value of a gas collecting hood in the oil filling process; and the control module is used for judging whether the injected object is provided with the vehicle-mounted refueling oil gas recovery system or not based on the pressure value of the gas collecting hood. According to the electronic oil gas recovery oil gun, a unique sealing structure is adopted, so that secondary oil gas recovery of a gas station is carried out in a relatively closed environment, air suction is effectively reduced, and the problem of excessive discharge caused by air suction of an underground oil tank is solved.

Owner:CHINA PETROLEUM & CHEMICAL CORP +1
Oil vapor recovery vacuum pump (with ORVR function)
1. The name of the design product: oil vapor recovery vacuum pump (with ORVR function). 2. The use of the design product: used for oil vapor recovery vacuum pump for oil vapor recovery fueling gun for various motor vehicles when refueling. 3. The design points of the design product: the combination of shape and pattern. 4. The picture or photo that best indicates the design points: perspective view 1.

Owner:SUZHOU CHISONG ELECTROMECHANICAL CO LTD
Identifying vehicle filling stations and generating related visual indications
Methods and systems for identifying vehicle filling stations and generating related visual indications are provided. In some examples, vehicle data is received that corresponds to a plurality of vehicles. From the vehicle data, a first subset of data is extracted that corresponds to location data and one of a fuel or charge level state change of each of the plurality of vehicles. One or more locations of one or more of the plurality of vehicles are identified, based on the location data, when the fuel or charge level state change corresponds to an increase in a fuel or charge level of the one or more of the plurality of vehicles. One or more visual indications are generated that correspond to the identified one or more locations.

Owner:MICROSOFT TECHNOLOGY LICENSING LLC
Device for a process for filling a tank with fuel, vehicle, and filling station
PCT designated stageWO2026046837A1Vessel mounting detailsVessel geometry/arrangement/sizeFuel tankAutomotive engineering
According to the invention, the technology disclosed here relates to a device (10) for a process for filling a tank with fuel, comprising a vibration unit (12) and a fuel nozzle (13) for a tank system (50) and / or a fuel coupling (14) for a filling station (200), wherein the vibration unit (12) can be activated in order to transmit a vibration to the fuel nozzle (13) and / or to the fuel coupling (14) in order to break up an ice coating (18) between the fuel nozzle (13) and the fuel coupling (14). The technology also relates to a vehicle (100) and to a filling station (200) comprising the device (10).

Owner:BAYERISCHE MOTOREN WERKE AG
Mobile fuel distribution station
Embodiments herein relate to a mobile fuel distribution station including a plurality of fuel tanks, one or more fuel pumps arranged to distribute fuel from said fuel tanks to users, a central fuel refill arrangement for refilling of one or more of said plurality of fuel tanks, and a fuel leakage prevention system, a central fuel refill arrangement and a fuel leakage prevention system arranged to prevent leakage from the central fuel refill arrangement, and from any of the plurality of fuel tanks. Other embodiments herein relate to a method and a system for predicting points of time for refilling fuel in one or more such mobile fuel distribution stations.

Owner:SECFUEL AB
Automatic oil gun grabbing method based on three-dimensional vision
The invention discloses an automatic oil gun grabbing method based on three-dimensional vision, and belongs to the technical field of automatic oil filling of fuel vehicles. According to the technical scheme, a depth camera is used for collecting video images, image processing is used for recognizing a grabbing hole and obtaining image data of the grabbing hole, a robot is controlled to change the pose, a conical connector connected with the robot is used for being connected with a fixing sleeve, and therefore the robot can accurately grab an oil gun; the grabbing hole is formed in the fixing sleeve connected with the oil gun. The method is achieved through an automatic grabbing system. The automatic grabbing system comprises processing equipment, input equipment, a displayer, a camera, a robot, a fixing assembly, a pneumatic device, an oil gun, an oil gun rack, a power source, a fixing sleeve and a conical connector. The device has the advantages of being accurate and reliable in measurement, light in grabbing structure, large in grabbing positioning range, stable, high in practicability and the like, can be widely applied to automatic refueling of gas stations, and has good economic benefits and wide market prospects.

Owner:SUZHOU AIFEILING INTELLIGENT TECH CO LTD
Cornice lamp box of gas station with aluminum alloy structure
The utility model provides a gas station cornice lamp box with an aluminum alloy structure, which relates to the technical field of advertisement display equipment and comprises an aluminum alloy frame and acrylic, and a mounting plate A is fixedly mounted on the side surface of the acrylic plate. The two-way lead screw A is driven to rotate by rotating the rotating head A, so that the movable plate can transversely move along the mounting plate B. In the same way, the rotating head B is rotated to drive the two-way lead screw B to rotate, so that the fixed plate can longitudinally move along the movable plate, and the position of the fixed hole can be transversely and longitudinally adjusted. Accurate installation in different gas station cornice environments is facilitated, the installation flexibility and adaptability are improved, the inserting blocks slide into the inserting grooves, when the limiting holes in the inserting blocks are aligned with the limiting rods, the limiting rods are automatically inserted into the limiting holes under the action of the tension springs, installation of the LOGO identification plate is completed, and the installation efficiency is improved. And when a certain LOGO identification plate is damaged, the LOGO identification plate can be conveniently replaced, so that the integrity of brand image display of the gas station is ensured.

Owner:CHANGCHUN JIANXIN ENG CONSULTING SERVICE CO LTD
Hydrogen Refueling IR Interference Shield
PendingJP2025509993AFuel cell auxillariesUnderstructuresInterference (communication)Computational physics
Described herein is an apparatus, an infrared (IR) interference shield, that may be utilized with a vehicle that utilizes hydrogen fuel, such as a fuel cell electric vehicle (FCEV). For example, the infrared interference shield is attached to a hydrogen fueling receptacle on the vehicle. The infrared interference shield is specifically structured to reduce or prevent interference in infrared wireless communications between a vehicle-side infrared transmitter on the receptacle and an infrared receiver at the hydrogen fueling station. The infrared interference shield may block interference to infrared signals that may adversely affect infrared wireless communications between the hydrogen fueling station and the vehicle. Thus, the infrared interference shield improves the reliability of communications between the vehicle and the hydrogen fueling station, thereby improving the overall effectiveness and efficiency of the hydrogen refueling process.

Owner:TOYOTA MOTOR ENG & MFG NORTH AMERICA INC
Device for temporarily storing automobile fuel tank cap in gas station
The utility model relates to the field of refueling equipment, in particular to an automobile fuel tank cap temporary storage device for a gas station, which is characterized in that a fuel tank cap storage bracket is mounted on a refueling gun body and comprises a fuel tank cap storage bearing platform and a fuel tank cap storage device connector; the fuel tank cap storage bearing platform is of a semicircular structure and is used for placing an automobile fuel tank cap; the fuel tank cap storage device connector is arranged below the fuel tank cap storage bearing platform, a clamping part is arranged at the bottom of the fuel tank cap storage device connector, and the fuel tank cap storage bracket is installed on the fuel gun body. The device is convenient and stable to install, long-term reliable use of the device is guaranteed, the operation convenience is improved, a refueling worker does not need to find a fuel tank cap placing position, the device can be used on a fuel gun during refueling, and the process is simplified. And after refueling is finished, the fuel tank cover can be taken out from the semicircular opening of the storage bracket to be installed in the vehicle fuel tank, the whole device enters a standby state immediately, recycling can be achieved, refueling operation every time can be efficiently and conveniently served, and the use cost is reduced.

Owner:CHINA NATIONAL PETROLEUM CORP YUNNAN KUNMING SALES BRANCH