
Patents
Literature
69 results about "Acceleration Unit" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
An object's acceleration is the net result of any and all forces acting on the object, as described by Newton's Second Law. The SI unit for acceleration is metre per second squared (m s−2). Accelerations are vector quantities (they have magnitude and direction) and add according to the parallelogram law.
Method for controlling mobile phone music player
InactiveCN103327186AEasy to controlImprove user experienceSubstation equipmentMusic playerMobile phone
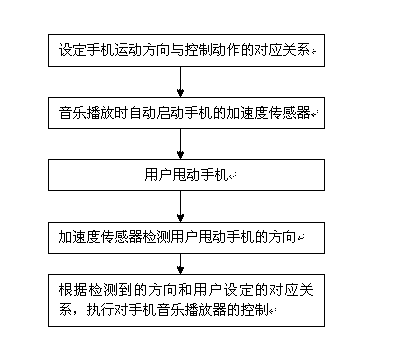
The invention discloses a method for controlling a mobile phone music player. The method includes the steps of enabling a user to set the corresponding relation between the moving directions of a mobile phone and control motions, when music is played in the background, automatically starting an acceleration sensor of the mobile phone, enabling the user to shake the mobile phone, enabling the acceleration sensor to detect the mobile phone shaking directions by the user, and carrying out control over the mobile phone music player according to the detected directions and the corresponding relation set by the user. The method for controlling the mobile phone music player can perceive the different mobile phone shaking directions by the user through the acceleration sensor so as to carry out the corresponding song switching operations or the corresponding volume adjustment operations, and the control of the user over the music player is greatly facilitated. In addition, due to the fact that the corresponding relation between the moving directions and the control motions can be preset by the user, user experience is strengthened.
Owner:润桐(苏州)技术服务有限公司
Collision detection method for high-reduction-ratio heavy-load mechanical arm
According to the collision detection method for the high-reduction-ratio and large-load mechanical arm, the problems of sensitivity and reliability of collision detection of the high-reduction-ratio mechanical arm are solved by combining a two-stage detection mechanism with tail end vibration characteristics and joint torque errors; according to the first-stage detection, tail end vibration signals are captured in real time through a three-axis acceleration sensor, and rapid recognition of slight collision is achieved; in the second-stage detection, joint torque errors are calculated based on current feedback, the nonlinear effect of the speed reducer is compensated in combination with a kinetic model, and the accuracy of violent collision detection is improved. High-precision collision identification and multi-level safety control of the mechanical arm and an external object under the heavy load working condition are achieved, and meanwhile the anti-interference capacity and reliability of a detection system under the complex working condition are improved.

Owner:CHANGZHOU VOCATIONAL INST OF ENG
Method for calculating acceleration and deceleration of each motion axis through stroke and vibration limitation
The invention relates to the technical field of multi-axis cooperative motion control, and discloses a method for calculating acceleration and deceleration of each motion axis by stroke and vibration limitation, which comprises the following steps of: S1, acquiring stroke data (Sx, Sy) of each motion axis and a preset acceleration resultant vector limit value; s2, based on the stroke data of each shaft and the acceleration resultant vector limit value, determining the total motion time T meeting the requirement of multi-shaft synchronous start and stop; and S3, according to the total motion time T, calculating acceleration and deceleration time (Tx0, Ty0) corresponding to each motion axis, and verifying whether an acceleration resultant vector meets a limiting condition or not. By combining real-time iterative optimization of total motion time T and acceleration and deceleration time, instantaneous acceleration and braking caused by a stepped track under high-speed motion are effectively suppressed, structural resonance and noise are reduced, constant-speed stage time and acceleration abrupt change rate are limited, a speed curve is further smoothed, high-frequency vibration energy transfer is reduced, and the high-speed vibration performance is improved. Therefore, the equipment operation stability is improved and the mechanical life is prolonged.

Owner:JIANGSU DAODA INTELLIGENT TECH CO LTD
Sensor data peak tracking
PendingUS20250370000A1Acceleration measurement using interia forcesSpeed/acceleration/shock instrument detailsAccelerometerExternal circuit
An acceleration sensor circuit is disclosed. The acceleration sensor circuit includes a package; an accelerometer to generate acceleration data samples during a peak tracking window; a sample register, to store the acceleration data samples; an acceleration calculation digital circuit, to calculate an acceleration magnitude sample based on the stored acceleration data samples; a peak register, to store a current peak acceleration value; a sample compare circuit, to compare the acceleration magnitude sample to the current peak acceleration value, where the peak register is configured to replace the current peak acceleration value with the acceleration magnitude sample in response to the sample compare circuit determining that the acceleration magnitude sample is greater than the current peak acceleration value; and a memory, configured to store the current peak acceleration value, and to transmit the current peak acceleration value to an external circuit in response to an end of the peak tracking window.


Owner:STMICROELECTRONICS INT NV
Roller conveyor with independent acceleration function
The invention relates to a roller conveyor with an independent acceleration function, and belongs to the technical field of conveying lines. Comprising a power and free conveying line, an acceleration driving assembly, a lifting assembly and a control system which are installed on a frame body. Wherein the power and free conveying line is used for conveying trays; the acceleration driving assembly is used for carrying out auxiliary acceleration on the trays to reach the conveying speed of the power and free conveying line; the lifting assembly is used for driving the acceleration driving assembly to get close to and away from the tray; and the control system is used for controlling operation of the power and free conveying line, the acceleration driving assembly and the lifting assembly. Through coordination and cooperation of the power and free conveying line, the acceleration driving assembly, the lifting assembly and the control system, the tray can obtain large acceleration, the stopping precision of the tray cannot be affected, the problem that the material carrying tray is slow to start again is solved, and the conveying efficiency is greatly improved.

Owner:MODULAR INDUSTRIAL AUTOMATION CO LTD
Positive end compression type acceleration sensor vibrator assembly assembling mechanism and assembling method
PendingCN121114492AAcceleration measurement using interia forcesSpeed/acceleration/shock instrument detailsPlate pressureAcceleration Unit
The invention relates to the technical field of positive-end compression type acceleration sensor vibration sub-assemblies, in particular to a positive-end compression type acceleration sensor vibration sub-assembly assembling mechanism and method.The positive-end compression type acceleration sensor vibration sub-assembly assembling mechanism comprises a pressure bench vice, a rotating supporting rod is arranged at the upper end of the pressure bench vice in a sliding mode, and an assembling pressing plate is arranged on the inner side of the pressure bench vice; a pressure gauge is arranged at the lower end of the pressure bench vice and used for sensing and outputting a pressure numerical value, and a jig limiting block is fixedly arranged at the lower end of the pressure bench vice and wraps the outer side of the pressure gauge. The position of the sub-assembly base placed on the inner side of the fixing sleeve can be corrected by arranging the correcting mechanism, the assembly pressing plate can be accurately pressed down for assembly, the position of the sub-assembly base can be rapidly fixed by arranging the limiting jig module, inclination caused by pressing down is prevented, and the assembly efficiency is improved. The effect of rapidly correcting and fixing the position of the sub-assembly is achieved, and the problem that the pressing assembly effect is affected due to the fact that the sub-assembly cannot be firmly fixed during assembly is solved.

Owner:ZHEJIANG GARDEN ELECTRONICS EQUIP
An inertia identification method based on double-frequency sinusoidal speed command
The application relates to the technical field of servo motor driving, and particularly discloses an inertia identification method based on double-frequency sinusoidal speed instructions, two different frequency sinusoidal speed instructions are sent to a motor by a servo driver, according to Newton's second law, a motion equation of a rotating system, a speed signal or an acceleration signal is multiplied by both sides of the motion equation of the rotating system, and integral operation is carried out in a complete period; for the test of the frequency omega1, the collected torque T e1 (t) is integrated with the acceleration, and thus the rotational inertia J can be directly solved. In the method, the speed instruction is a sinusoidal wave, compared with the trapezoidal acceleration and deceleration method and the step response method, the instruction is smoother, mechanical impact is small, and in addition, technical difficulties existing in the single-frequency sinusoidal excitation method can be avoided.

Owner:NANJING DAFENG NUMERICAL CONTROL TECH CO LTD
Vehicle acceleration calculation method and device
This invention discloses a method and apparatus for calculating vehicle acceleration. The method establishes gravitational acceleration component equations based on a first set of acceleration models and a second set of acceleration models. It determines the total acceleration vector of a second sensor based on the vector coordinates of the second coordinate system relative to the first coordinate system. Based on the vector coordinates of the second coordinate system relative to the first coordinate system, it calculates the total rotational angular velocity vector and the total rotational angular acceleration vector of the second sensor in the first coordinate system. Based on the total acceleration vector, the total rotational angular velocity vector, and the total rotational angular acceleration vector, it calculates the summed acceleration vector of the second sensor at the origin of the first coordinate system. Based on the resultant acceleration vector and the summed acceleration vector in the first coordinate system, it establishes acceleration equations. Finally, it establishes and solves a joint system of equations based on the gravitational acceleration component equations and the acceleration equations to obtain the motion acceleration of each axis in the first coordinate system. This method improves the accuracy of vehicle acceleration calculation.

Owner:DONGFENG OFF ROAD VEHICLE CO LTD
Intramedullary acceleration testing device
ActiveCN120142696BMaterial exposibilityAcceleration measurementMechanical engineeringMicro power source
The application is a kind of medium internal acceleration testing device. It comprises a carrier, a cover, a support assembly and a hanging sleeve assembly. The carrier is used for fixing and installing an acceleration sensor. The cover is buckled on the carrier. The support assembly comprises a base plate fixed on the top of the cover, a micro power source installed on the base plate and a plurality of lifting rods hinged to the base plate. A through slot is formed on the base plate. The micro power source can drive the plurality of lifting rods to pivot and abut against the inner wall of the hole to be finally fixed. The hanging sleeve assembly is used for being clamped by a clamp. It is connected with the base plate through a pulling assembly and can be separated from the clamp downward during the abutting process of the plurality of lifting rods and the inner wall of the hole. The acceleration sensor plays a role of isolation and protection. It will not be invaded by liquid in the medium inside. The sensitive surface of the acceleration sensor can be determined outside. The sensitive surface of the acceleration sensor points to the explosion with high stability. The filling material is not easy to deviate.

Owner:ARMY ENG UNIV OF PLA
Simulator
To provide a simulator capable of appropriately reproducing acceleration acting on a user.SOLUTION: The control unit of the simulator receives the squaring angle detected by the first detecting unit or the squaring angle calculated from the angular velocity detected by the first detecting unit and the angle of attack detected by the second detecting unit, calculating an inertial force generated in the support plate in the turn action from an equation of motion related to a gravity of the user acting on the support plate, a frictional force between the support plate and the reference surface, and an air resistance acting on the user in the turn action, using a friction coefficient between the support plate and the reference surface in the turn action as a sum of a first friction coefficient between the support plate and the reference surface in a carving turn action in which the turn action is performed in a state of being inclined in the roll direction and a second friction coefficient between the support plate and the reference surface in a squatting turn action in which the turn action is performed so as to rotate in the yaw direction; The turning radius of the support plate in the turn operation is calculated, and the driving part is controlled based on the calculation result.SELECTED DRAWING: Figure 1

Owner:MITSUBISHI HEAVY IND MACHINERY SYST LTD
A method for modifying acceleration load calculation formula for pipeline stress analysis
The application discloses a kind of acceleration load calculation formula correction method for pipeline stress analysis, comprising the following steps: 1) based on potential flow theory, diffraction theory, establish ship motion equation;2) in AQWA software, the ship length, type width, type depth, design draft, displacement, inertia moment of general FPSO are input, time domain analysis is carried out, and its hydrodynamic coefficient is obtained, then acceleration load extreme value is predicted using SESAM software;3) according to the ship length, type width, type depth of general FPSO, design draft, structural draft, displacement under different working conditions, the acceleration of each degree of freedom is calculated according to ship motion acceleration load calculation formula;4) error analysis is carried out to the acceleration value calculated in steps 2), 3), and the acceleration formula calculation value needs to be corrected if the error is greater than d;5) introduce correction coefficient f, and the acceleration calculation value with error greater than d is corrected until the error is less than d;6) the corrected acceleration can be applied on the pipeline as acceleration load.

Owner:JIANGSU UNIV OF SCI & TECH
A portal lifting stability control feedback system and method applied to a forklift AGV
The application discloses a portal lifting stable control feedback system and method applied to a forklift AGV, and the system comprises an IMU, an abnormality judgment module, a speed planning module, a feedforward item determination module, a PID control module and a valve control module. The IMU outputs acceleration data; the abnormality judgment module determines a portal lifting abnormality judgment result according to the acceleration data; the speed planning module obtains a target speed and determines a target acceleration when the portal lifting is not abnormal; the feedforward item determination module determines vertical motion state corresponding data of the portal at the current moment according to the acceleration data, and determines a feedforward item according to the target acceleration and the vertical motion state corresponding data; the PID control module determines a compensated speed tracking control instruction according to the target speed and the feedforward item; and the valve control module determines a proportional valve opening degree according to the control instruction, and executes deceleration stop control when the portal lifting is abnormal. The application can improve the consistency between the portal lifting control and the actual motion state and the operation stability.

Owner:SHENZHEN NIPPTON ROBOT CO LTD
Servo motor PID position pointing smooth optimization method based on acceleration feedback
ActiveCN122026758AElectronic commutation motor controlVector control systemsLow speedClassical mechanics
The invention discloses a servo motor PID position pointing smooth optimization method based on acceleration feedback, and belongs to the technical field of motor control. The method comprises the following steps: acquiring PID parameters, a motor target position and in-place preset time; determining an acceleration section, a deceleration section and an adjustment section in the travel according to the starting point and the target position; executing acceleration section three-loop PID control, and adjusting a position loop command value according to acceleration feedback; executing deceleration section three-ring PID control, and adjusting a position ring command value according to acceleration feedback; adjusting section PID control is executed, and the position loop command value is kept at the final position; according to the invention, the position ring command value during execution of each position ring can be dynamically adjusted according to real-time acceleration measurement and calculation, so that the movement speed of the motor from the initial position to the final position is ensured to be a smooth acceleration-first deceleration-second movement curve; the target position is approached at a low speed, so that the position, speed overshoot and in-place position fluctuation can be effectively reduced, and the pointing precision of the servo motor is remarkably improved.

Owner:SHANGHAI INSTITUTE OF TECHNICAL PHYSICS CHINESE ACADEMY OF SCIENCES
A method and apparatus for detecting door intrusion stimuli
PCT designated stageWO2025190881A1Burglar alarm with fastening tamperingVibration measurement in solidsSimulationAcceleration Unit


Owner:UAP
Detection device and detection method
To provide a detection device and a detection method capable of easily discriminating an abnormality occurrence place of an injection molding device.SOLUTION: The detection device 2 according to the present disclosure includes an acceleration information acquisition unit 21, an acceleration abnormality detection unit 22, and an output unit 23. The acceleration information acquisition unit 21 acquires acceleration information of the plunger during the injection operation. The acceleration abnormality detection unit 22 detects an acceleration abnormality of the plunger in the injection direction and the direction perpendicular to the injection direction based on the acceleration information. The output unit 23 outputs abnormality detection information on the drive mechanism of the plunger when the acceleration abnormality detection unit 22 detects the acceleration abnormality in the injection direction and does not detect the acceleration abnormality in the direction perpendicular to the injection direction.SELECTED DRAWING: Figure 2

Owner:TOYOTA JIDOSHA KK
Detection device and detection method
PendingCN121339362ACasting parameters measurement/indication devicesAnomaly detectionInjection - action
Provided are a detection device and a detection method with which it is possible to easily discriminate a location where an abnormality occurs in an injection molding device. A detection device (2) according to the present disclosure is provided with an acceleration information acquisition unit (21), an acceleration abnormality detection unit (22), and an output unit (23). An acceleration information acquisition unit (21) acquires acceleration information of a plunger during an injection operation. An acceleration abnormality detection unit (22) detects an acceleration abnormality of the plunger in the injection direction and a direction perpendicular to the injection direction on the basis of the acceleration information. The output unit (23) outputs abnormality detection information pertaining to the drive mechanism of the plunger when the acceleration abnormality detection unit (22) detects an acceleration abnormality in the injection direction and does not detect an acceleration abnormality in a direction perpendicular to the injection direction.

Owner:TOYOTA JIDOSHA KK
A speed generating device
The present invention discloses a speed generating device, comprising a table body and two handles on the outer wall of the table body. The table body is provided with a driving system installed inside the table body. The output shaft of the driving system is connected to a precision shaft system through a coupling. A work table is installed on the end of the precision shaft system. The precision shaft system is used to transmit the driving force of the driving system to the work table surface. The object to be measured is installed on the work table surface. The driving system can provide linear velocity, angular velocity and acceleration for the object to be measured. During operation, the present invention drives the work table surface to rotate through the provided driving system, provides the object to be measured with motion velocity, angular velocity and acceleration, facilitates the simultaneous detection of multiple devices, improves the detection efficiency, adopts a control method of directly driving the work table surface with a high-performance rare earth permanent magnet servo motor, is convenient to control, has a light weight and a small moment of inertia, improves the test rate accuracy, and protects the work table surface through a top cover, improves the detection accuracy.

Owner:JIANGXI NAVIGATION APP FACTORY
Acceleration sensor stable assembly component for elevator construction test
The utility model relates to the technical field of assembly components, and discloses an acceleration sensor stable assembly component for elevator construction test, which comprises a protection box main body and a protection mounting mechanism, the protection mounting mechanism comprises a positioning bottom plate vertically and slidably connected in the protection box main body, the protection mounting mechanism further comprises top limiting blocks bonded to the two sides of the inner wall of the protection box body. According to the utility model, through the arrangement of the protection box main body and the protection installation mechanism, the periphery of the acceleration sensor can be stored and protected through the protection box main body, when the top limiting block is not extruded any more, the acceleration sensor below is positioned and fixed, and when the acceleration sensor needs to be taken down, the protection box is convenient to use. And the acceleration sensor in the protection box main body can be quickly driven to move by shifting the positioning bottom plate positioned below the acceleration sensor.

Owner:SICHUAN YANSEN CONSTRUCTION CO LTD
A method for predicting a satellite orbit
This application relates to a satellite orbit prediction method. The method includes: constructing an expression for the gravitational force acting on the satellite based on its mass and distance from Earth; constructing a differential equation for the satellite's acceleration based on Newton's second law and the expression for the gravitational force; solving the differential equation based on the conservative force field characteristics of mechanics, calculating the gravitational potential energy function and its derivative with respect to time; transforming the derivative expression based on the mechanical conservation law that the sum of the derivatives of kinetic energy and gravitational potential energy with respect to time is zero, to obtain the derivative expression for acceleration; converting the time relationship in the derivative expression of acceleration to a radial position relationship based on the principle of conservation of angular momentum; integrating the radial position relationship to obtain the satellite's orbit equation. This method enables satellite orbit prediction.

Owner:NAT UNIV OF DEFENSE TECH
Absolute calibration device and method for acceleration sensor under ultrahigh acceleration condition
PendingCN121276093ATesting/calibration of speed/acceleration/shock measurement devicesAbsolute calibrationHigh acceleration
The invention discloses an absolute calibration device and method for an acceleration sensor under an ultra-high acceleration condition, and the device is characterized in that a loading force value and carrier mass are known values, namely, under the condition that an acceleration value is known, an unloading stress impact method is used for enabling a stand column bearing the carrier mass to generate rebound stress; the carrier with the acceleration sensor is impacted to generate high-frequency and high-acceleration motion, and the voltage output response of the sensor is measured, so that the amplitude-frequency characteristic of the acceleration sensor under the high-frequency and high-acceleration condition is obtained. When the cross spring bears the carrier mass block, the unloading force is changed into the vibration force of the spring, and a response value of low-frequency excitation in the sensor can be generated. The acceleration sensor is a double-second-order oscillation system, and the sensitivity is a function of the carrier mass, the rigid connection strength and the sensor installation direction, so that the influence degree of the parameters can be measured through structure adjustment, and ideal calibration that the vibration mass block in the acceleration sensor is only acted by acceleration force can be realized; the technology cannot be realized in the prior art.

Owner:方继明
Motion measurement apparatus and method of measuring motion of a wheel
PendingUS20250237578A1Acceleration measurement using interia forcesInflated body pressure measurementClassical mechanicsMechanical engineering

Owner:MELEXIS TECHNOLOGIES SA
Train body coating structure testing method, device, equipment and medium
PendingCN121347092AMaterial strength using repeated/pulsating forcesVibration testingSimulationStructural engineering
The invention provides a test method, device and equipment for a train body coating structure and a medium, and the method comprises the steps: obtaining acceleration data detected by at least one sensor in a train operation process; based on the mathematical model of the vehicle body coating structure, determining a mapping relation between the vehicle body coating structure and a load; reversely deducing a test spectrum based on the acceleration data and the mapping relation; and the test spectrum is transmitted to a vibration table, so that when the vibration table vibrates according to the test spectrum, fatigue test is performed on the to-be-tested vehicle body coating structure. According to the method, the test spectrum which can be applied to the vibration table can be obtained, so that the fatigue test is performed on the vehicle body coating structure under the condition that the load of a real driving scene is restored.

Owner:CRRC CHANGCHUN RAILWAY VEHICLES CO LTD
Method and system for implementing boxing motion analysis
PendingUS20260115533A1Speed measurement using accelerationGymnastic exercisingTime segmentQuaternion
A method for implementing boxing motion analysis includes: obtaining, from an inertial measurement unit (IMU) on a user, acceleration data at a plurality of time instances within a time period; performing a dynamic adjustment operation on the acceleration data to obtain adjusted acceleration data; performing a signal cutting operation based on the adjusted acceleration data, three average acceleration values when the IMU is in a stationary state, and three threshold values, so as to obtain a plurality of time segments each associated with one swing motion; and performing, with respect to each of the time segments, a quaternion calculation, so as to obtain rotational acceleration data, performing a first integration operation and a second integration operation to obtain a plurality of locations of the IMU over the time segment, and obtaining a trajectory of the IMU in the time segment.

Owner:NATIONAL TSING HUA UNIVERSITY
Calibration and error compensation method for high-precision double-shaft inclinometer
PendingCN121327319AMeasurement devicesComplex mathematical operationsThree axis accelerometerMechanical engineering
The invention discloses a high-precision double-shaft inclinometer calibration and error compensation method, which comprises the following steps: a three-dimensional error model is established for a double-shaft inclinometer, and the three-dimensional error model is formed by combining scale factor terms of two shafts, cross coupling terms of the two shafts, quadratic term coefficients and zero offset terms of the two shafts; z-axis acceleration estimation is carried out by using the condition that the sum of the three-axis acceleration vectors is equal to gravitational acceleration as a constraint condition; converting the three-dimensional error model into a residual function through a nonlinear least square algorithm, and solving a target function; and carrying out iterative optimization on the error model based on an LM algorithm, and carrying out compensation aiming at the characteristic that the inclination angle output error is periodic to obtain a high-precision measurement value. According to the invention, the acceleration input in the third axial direction is estimated only by the accelerometers in the two horizontal axial directions, so that the problem that the Z-axis installation error cannot be solved by a traditional double-axis inclinometer is solved. Compared with an inclinometer adopting a three-axis accelerometer scheme, the inclinometer has the advantage that the hardware cost is reduced.

Owner:BEIJING KUNDI ELECTRONIC TECHNOLOGY CO LTD
S-shaped curve planning method for minimizing maximum speed and maximum acceleration
PendingCN120803094ANon-mechanical conveyorsSpeed/accelaration control using electric meansComputational physicsEnergy consumption
The invention belongs to the technical field of magnetic suspension motion control methods, and particularly relates to an S-shaped curve planning method for minimizing the maximum speed and the maximum acceleration. A displacement stroke threshold value is solved according to the parameters, whether the displacement stroke threshold value is smaller than a given total stroke or not is judged to determine whether a first T-shaped curve or a triangular curve is used, and the shortest time of each curve under the acceleration threshold value and the speed threshold value is solved; respectively judging the relationship between the shortest time and the given total time; under the first T-shaped curve, the maximum acceleration is selectively reduced or the maximum speed is firstly reduced and then the maximum acceleration is reduced according to the relation between the first difference value and the duration time of the first maximum speed; if the shortest time under the triangular curve is smaller than the given total time, the maximum speed is reduced, the triangular curve is changed into a second T-shaped curve, then the maximum acceleration is reduced, and a four-section mode or a six-section mode is adopted; and a distribution coefficient alpha is input, a speed curve which meets the requirement and is more stable is determined according to whether the alpha is smaller than a threshold value under each condition, and the energy consumption of the system is lower.

Owner:WUXI MINHANG INTELLIGENT CONTROL SYST CO LTD
Acceleration calculation device
PendingJP2026005443ATesting/calibration of speed/acceleration/shock measurement devicesWheel speed sensorMechanical engineering
To provide an acceleration calculation device capable of continuing to calculate estimated acceleration of a vehicle even when either an acceleration sensor or a wheel speed sensor is abnormal.SOLUTION: When the acceleration sensor 300 and the wheel speed sensor 400 are both normal (S210: NO), the acceleration calculation device calculates the estimated acceleration eA using the first acceleration AG and the second acceleration AW. When the acceleration sensor 300 is normal and the wheel speed sensor 400 is abnormal (S210: YES), the acceleration calculation device calculates the estimated acceleration eA using only the first acceleration AG out of the first acceleration AG and the second acceleration AW. When the acceleration sensor 300 is abnormal and the wheel speed sensor 400 is normal (S220: NO), the acceleration calculation device calculates the estimated acceleration eA using only the second acceleration AW out of the first acceleration AG and the second acceleration AW.SELECTED DRAWING: Figure 3

Owner:TOYOTA JIDOSHA KK +2
Workpiece anti-slip motion control method for a video measuring machine stage
The application discloses a workpiece anti-slipping motion control method for a worktable of a video measuring instrument, and steps include presetting a control speed curve equation, respectively determining a corresponding acceleration curve equation and a displacement curve equation; based on a workpiece target moving distance, a preset moving speed and a maximum acceleration, simultaneously solving the speed curve equation and the acceleration curve equation, and solving unknown constant terms in the equation; using a grating ruler to obtain a real-time position of the workpiece, based on the solved control speed curve equation and the displacement curve equation, solving a motion time through a Newton iteration method; and substituting the motion time into the solved control speed curve equation to obtain an expected motion speed. The application can completely eliminate workpiece slipping, avoid setting a tool clamp and manual clamping, and effectively improve continuous measurement efficiency.

Owner:LANHAI PHOTOELECTRICITY TECH CO LTD
Step counting method and device
The present application discloses a step counting method and device. The step counting method includes: obtaining a first acceleration, a second acceleration, and a third acceleration of three axes of an acceleration sensor in a terminal device within a preset time period, where the first acceleration, the second acceleration, and the third acceleration are perpendicular to each other pairwise in the acceleration direction; determining a motion change amount of the user within the preset time period based on the first acceleration, the second acceleration, and the third acceleration within the preset time period; and determining the number of steps of the user within the preset time period based on the resultant acceleration of the first acceleration, the second acceleration, and the third acceleration and the gravitational acceleration within the preset time period when the motion change amount of the user within the preset time period is greater than or equal to a preset variance threshold.

Owner:VIVO MOBILE COMM CO LTD
I-shaped steel web position fixing device of acceleration sensor
ActiveCN223635864UMachine supportsNon-rotating vibration suppressionStructural engineeringControl theory
The utility model provides an I-shaped steel web position fixing device of an acceleration sensor, which belongs to the technical field of fixing devices and comprises an acceleration sensor mounting base, a first adjustable support rod, a first anti-slip base, a second adjustable support rod and a second anti-slip base. A first adjustable supporting rod is arranged above the acceleration sensor mounting base, one end of the first adjustable supporting rod is connected with the acceleration sensor mounting base, the other end of the first adjustable supporting rod is connected with a first anti-skid base, and a second adjustable supporting rod is arranged below the acceleration sensor mounting base; one end of the second adjustable supporting rod is connected with the acceleration sensor mounting base, and the other end of the second adjustable supporting rod is connected with the second anti-skid base. The fixing device overcomes the defects that when an acceleration sensor is mounted on an I-shaped steel web, the structural strength is damaged, and the adaptability is poor in a traditional fixing device.

Owner:THE FIRST COMPARY OF CHINA EIGHTH ENG BUREAU LTD
Trajectory constraint device and trajectory constraint method
The present invention imparts mechanical characteristics such as elasticity and viscosity when constraining the trajectory of a controlled object onto a figure (a two-dimensional figure or a three-dimensional spatial figure) defined by a signed distance function (SDF). In a trajectory constraint device 1, a rotational angle position of a robot arm 10 is converted into end tip position information using a command value input for a signed distance, and the signed distance between the position information and a bound trajectory is calculated. When the signed distance is being controlled, an acceleration reference value expressed by formula (3) is calculated using a velocity gain and position gain representing virtual elasticity and viscosity. Said acceleration reference value is multiplied with a calculated result of a unit vector applied to a partial differential of the signed distance XSD, converting into an acceleration reference value expressed by formula (4). This acceleration reference value is converted into an acceleration reference value expressed by formula (12) to rotate each shaft of the robot arm 10. The inertia of the rotational angle direction of each shaft is then multiplied by this acceleration reference value, the torque of each shaft is controlled by determining a torque reference value for each shaft, and the trajectory of the robot arm 10 is constrained.

Owner:MEIDENSHA CORP