
Patents
Literature
46 results about "Spurline" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
The spurline is a type of radio-frequency and microwave distributed element filter with band-stop (notch) characteristics, most commonly used with microstrip transmission lines. Spurlines usually exhibit moderate to narrow-band rejection, at about 10% around the central frequency.
Novel broadband printed dipole antenna with branch wire integrated with feed balun
ActiveCN103531895AHigh bandwidthDoes not affect other performanceRadiating elements structural formsResonant antenna detailsSpurlineAntenna bandwidth
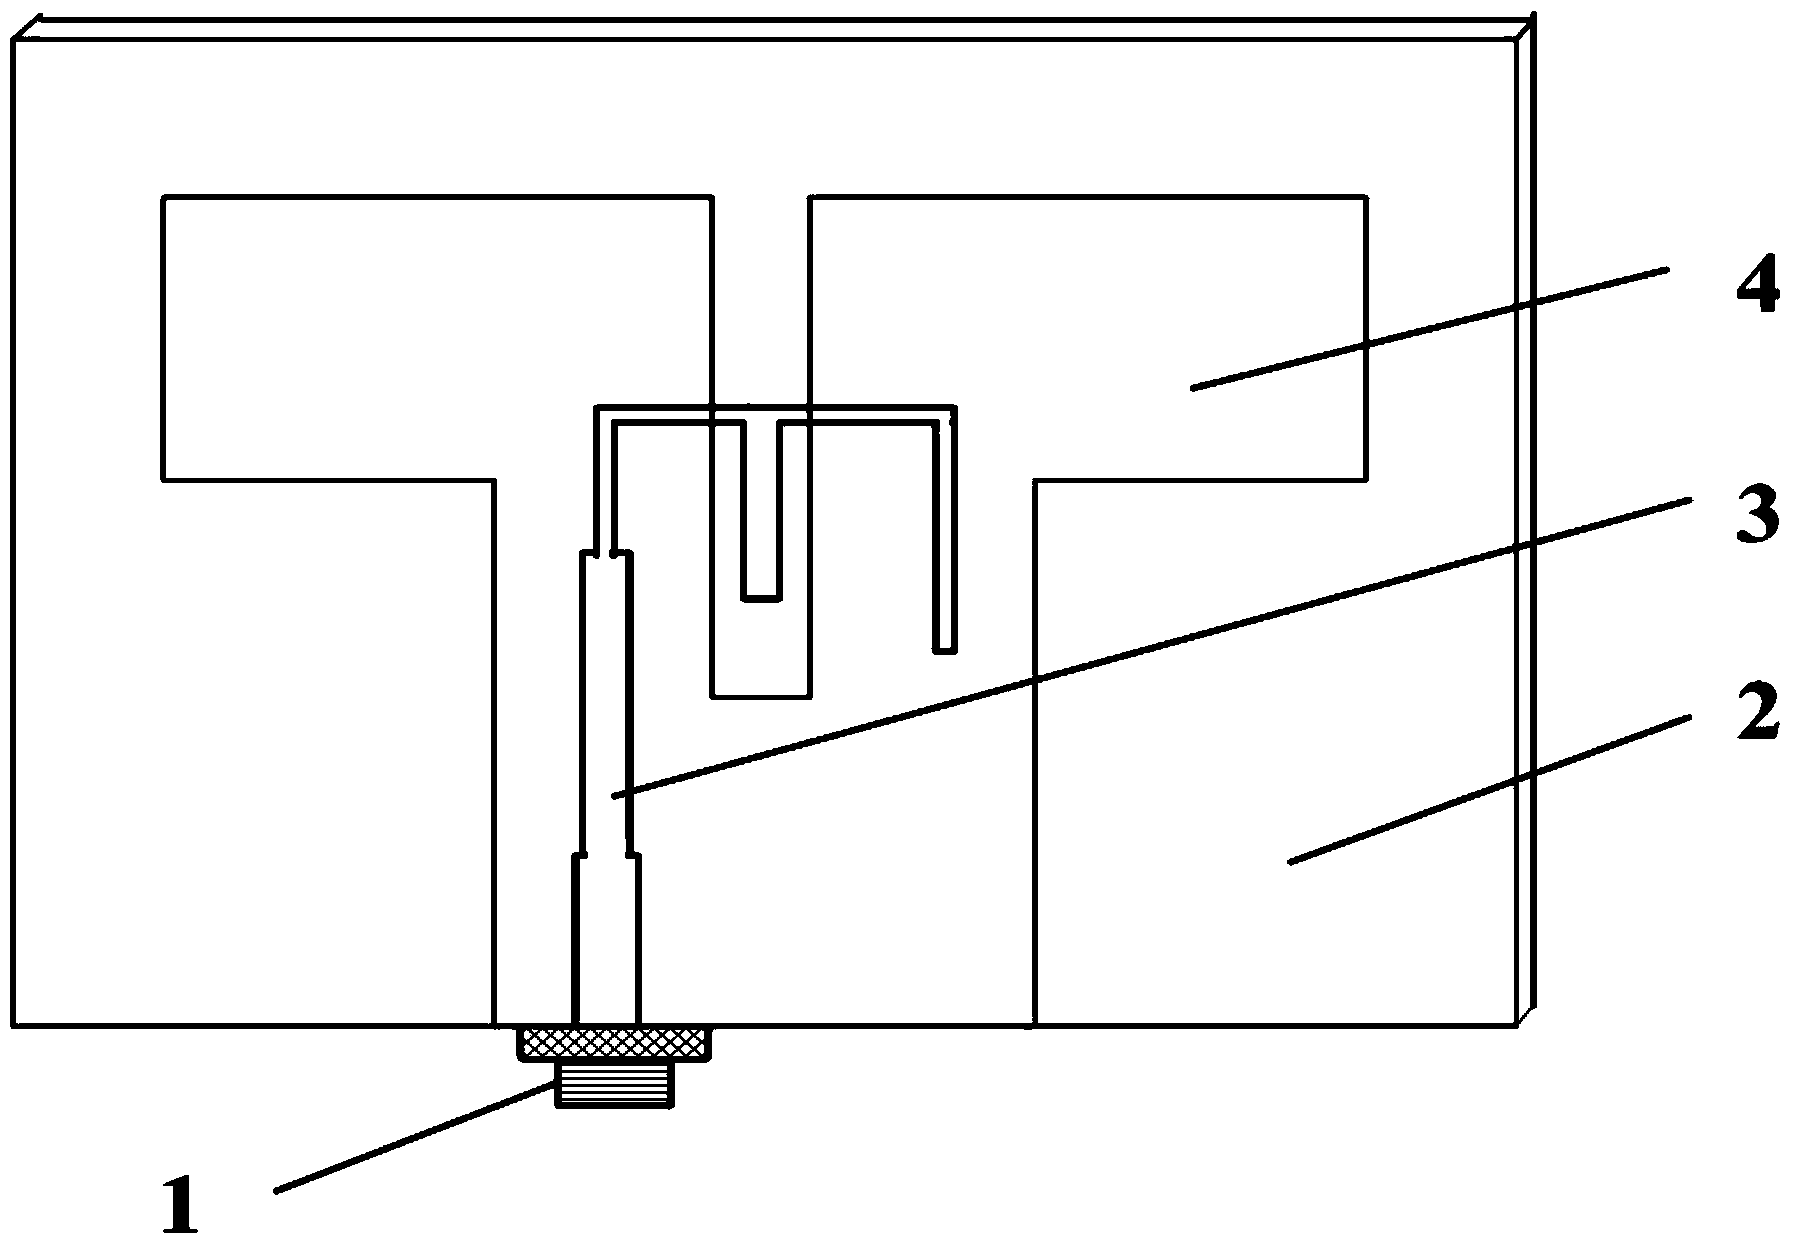
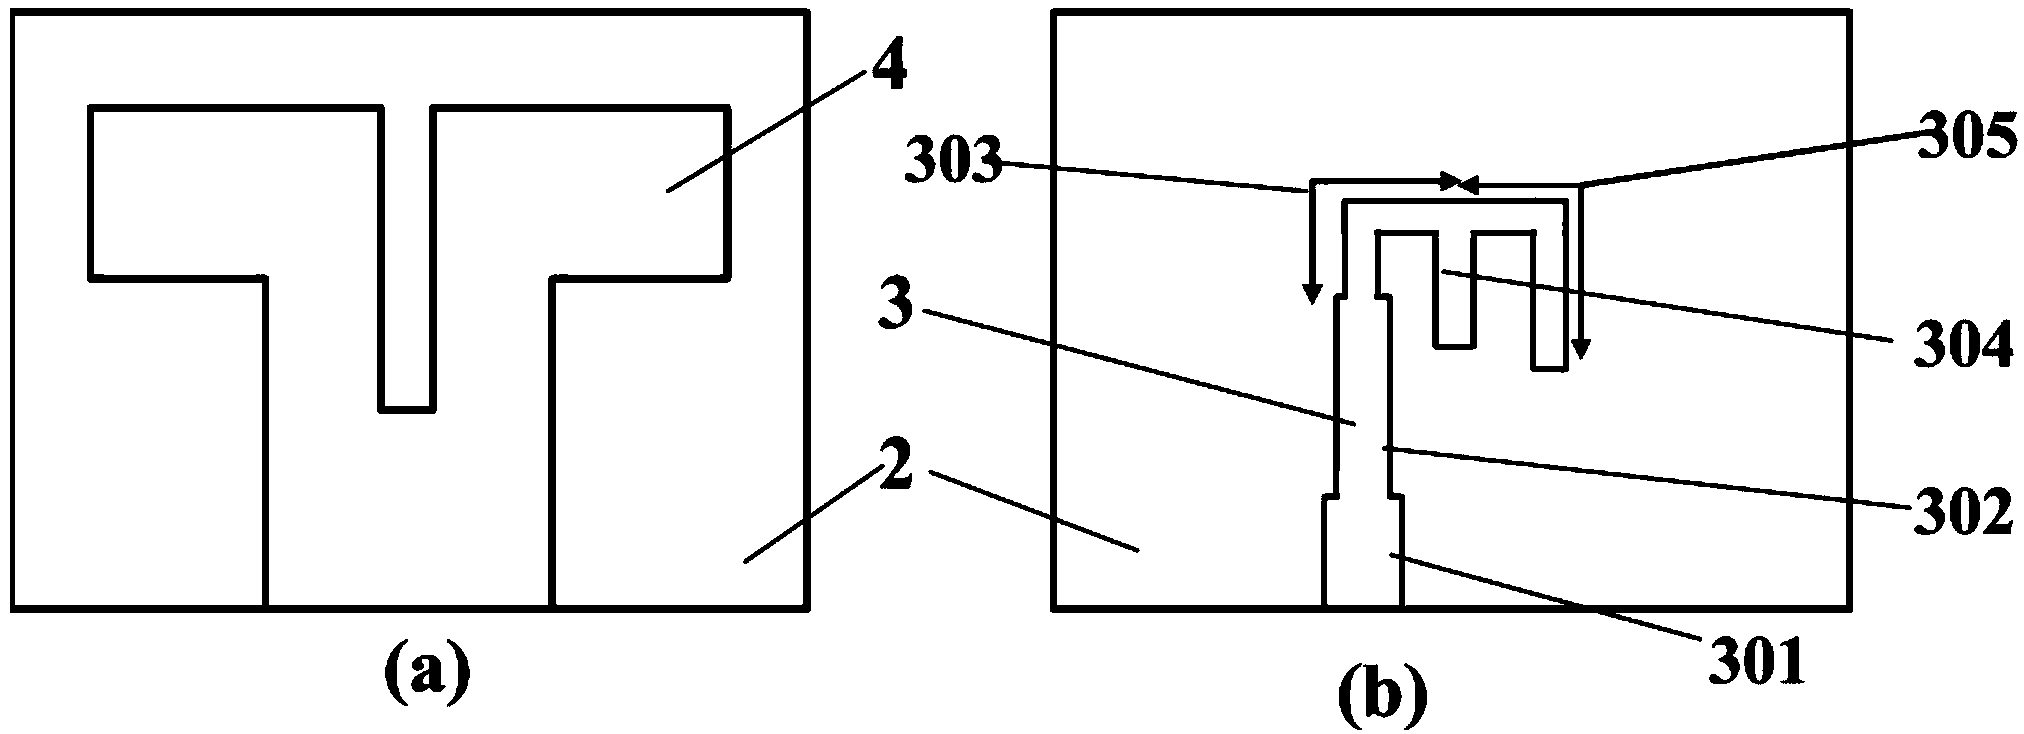
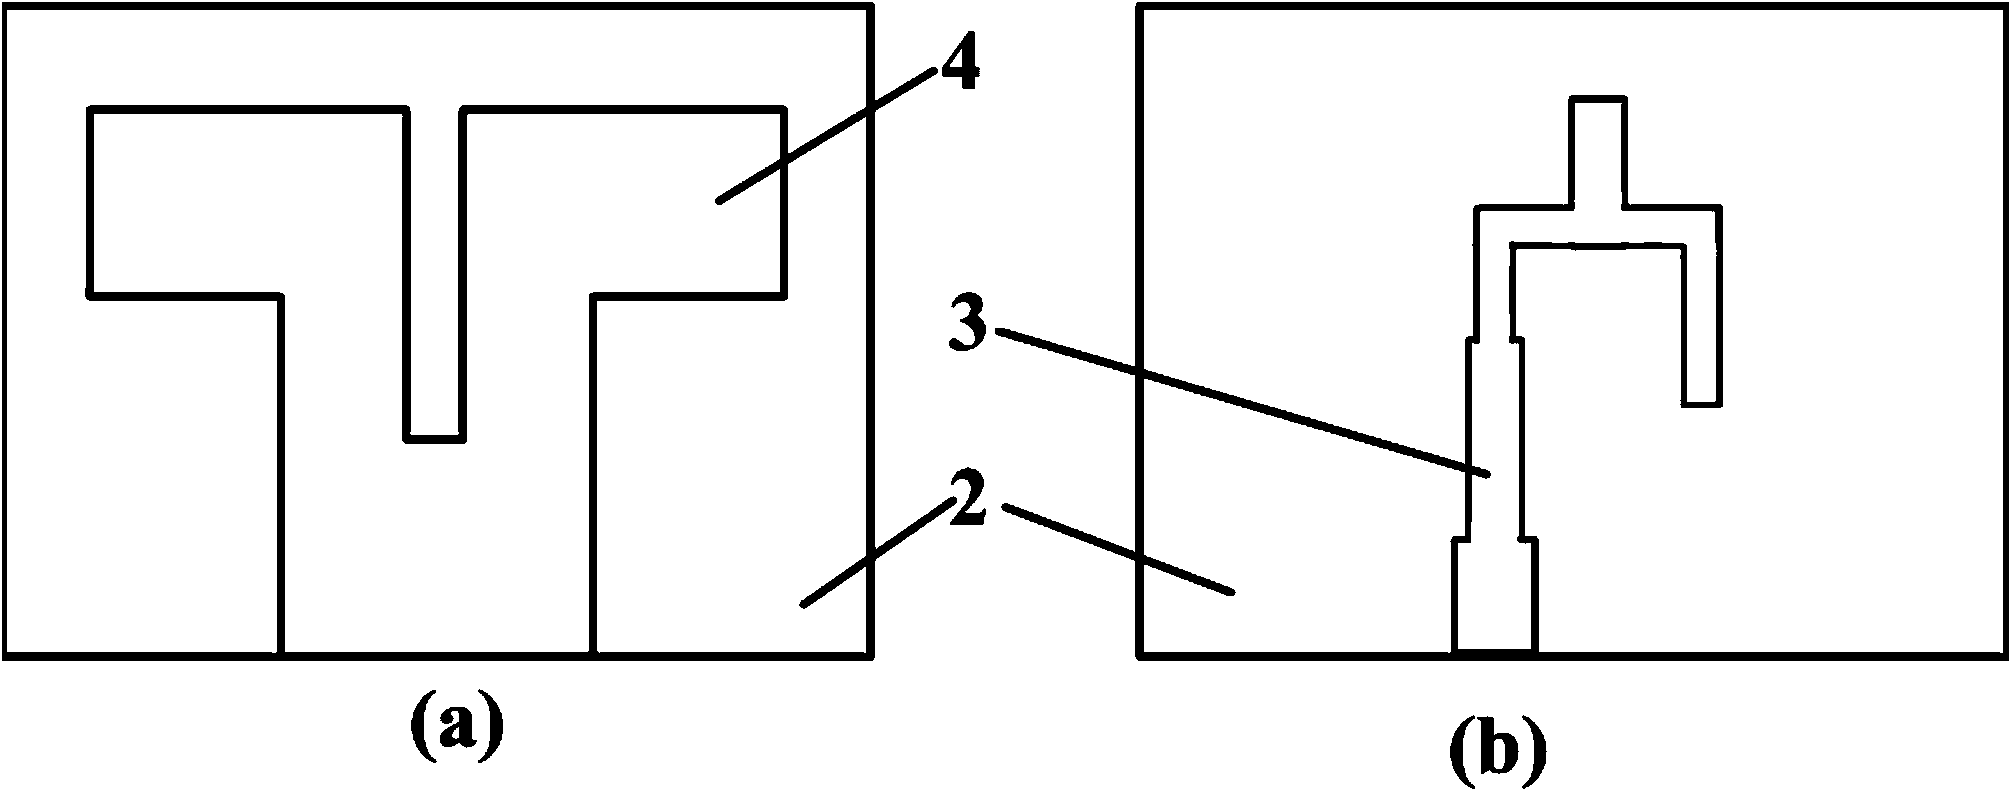
The invention discloses a novel broadband printed dipole antenna with a branch wire integrated with a feed balun. The novel broadband printed dipole antenna comprises an SMA (Shape Memory Alloy) joint, a dielectric-slab, a radiating element and a microstrip line feed integrated balun, wherein the radiating element is provided with a slotting seam; dual radiation arms are formed on both sides of the slotting seam; the microstrip line feed integrated balun is provided with a branch wire; the branch wire is equivalent to a series resistor, and is used for improving the matched impedance. According to the novel broadband printed dipole antenna, the VSWR (Voltage Standing Wave Ratio) is less than or equal to 1.5, and the relative bandwidth is up to 58.7 percent (1.65-3.0GHz); compared with other bandwidth extension technologies (such as a parasitic patch increasing technology), the novel broadband printed dipole antenna has the advantages that design is made on the basis of not changing the original size of the antenna, so that the bandwidth of the antenna is improved, other performance of the antenna (such as gain and cross polarization level) is not influenced, and the occupied space is reduced; the novel broadband printed dipole antenna has the advantages of simple structure, convenience, practicability, wide adaptability and the like.
Owner:HUAQIAO UNIVERSITY
Combined microwave sensor and dielectric constant measurement method for measured object
ActiveCN107490727AAccurate measurementAccurate and reliable measurement resultsResistance/reactance/impedenceSpurlineDielectric permittivity
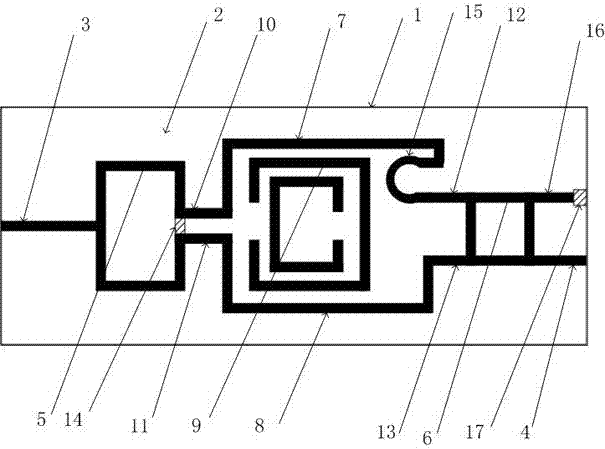
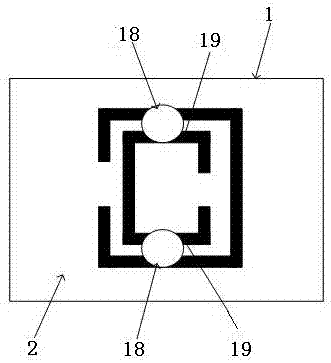
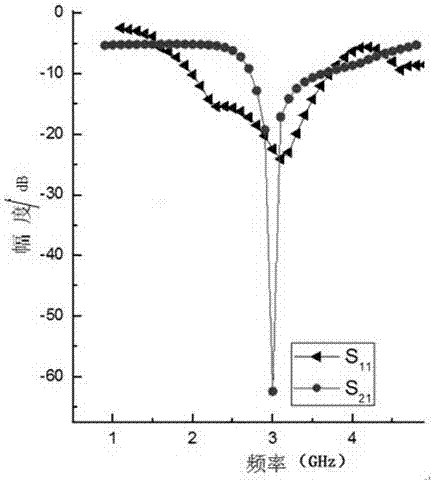
A combined microwave sensor comprises metal ground at the bottom layer, dielectric at the middle layer, an input port, an output port I, a branched line coupler, a power divider, an open resonant ring, a microstrip line I and a microstrip line II, wherein the input port, the output port I, the branched line coupler, the power divider, the open resonant ring, the microstrip line I and the microstrip line II are arranged in the top layer. The input port and the output port I are connected with a vector network analyzer. The output side of the branched line coupler is provided with an isolated port and the output port I. The input end of the power divider is connected with the input port. The output port II and the output port III are connected with an annular directional coupler through a microstrip line. The open resonant ring is arranged between the power divider, the branched line coupler and the two microstrip lines. The combined microwave sensor has advantages of effectively eliminating background noise, realizing testing for weak background signals, and ensuring large offset of the sensor resonant frequency through small disturbance of the tested object. Therefore the combined microwave sensor provided by the invention has higher sensitivity and higher accuracy in dielectric constant measurement and can be used in high-sensitivity testing with small dielectric constant change.
Owner:HENAN NORMAL UNIV
Pixel construction and thin-film transistor thereof
InactiveCN101359692AConstant feedthrough voltageTransistorSemiconductor/solid-state device detailsSpurlineLine width
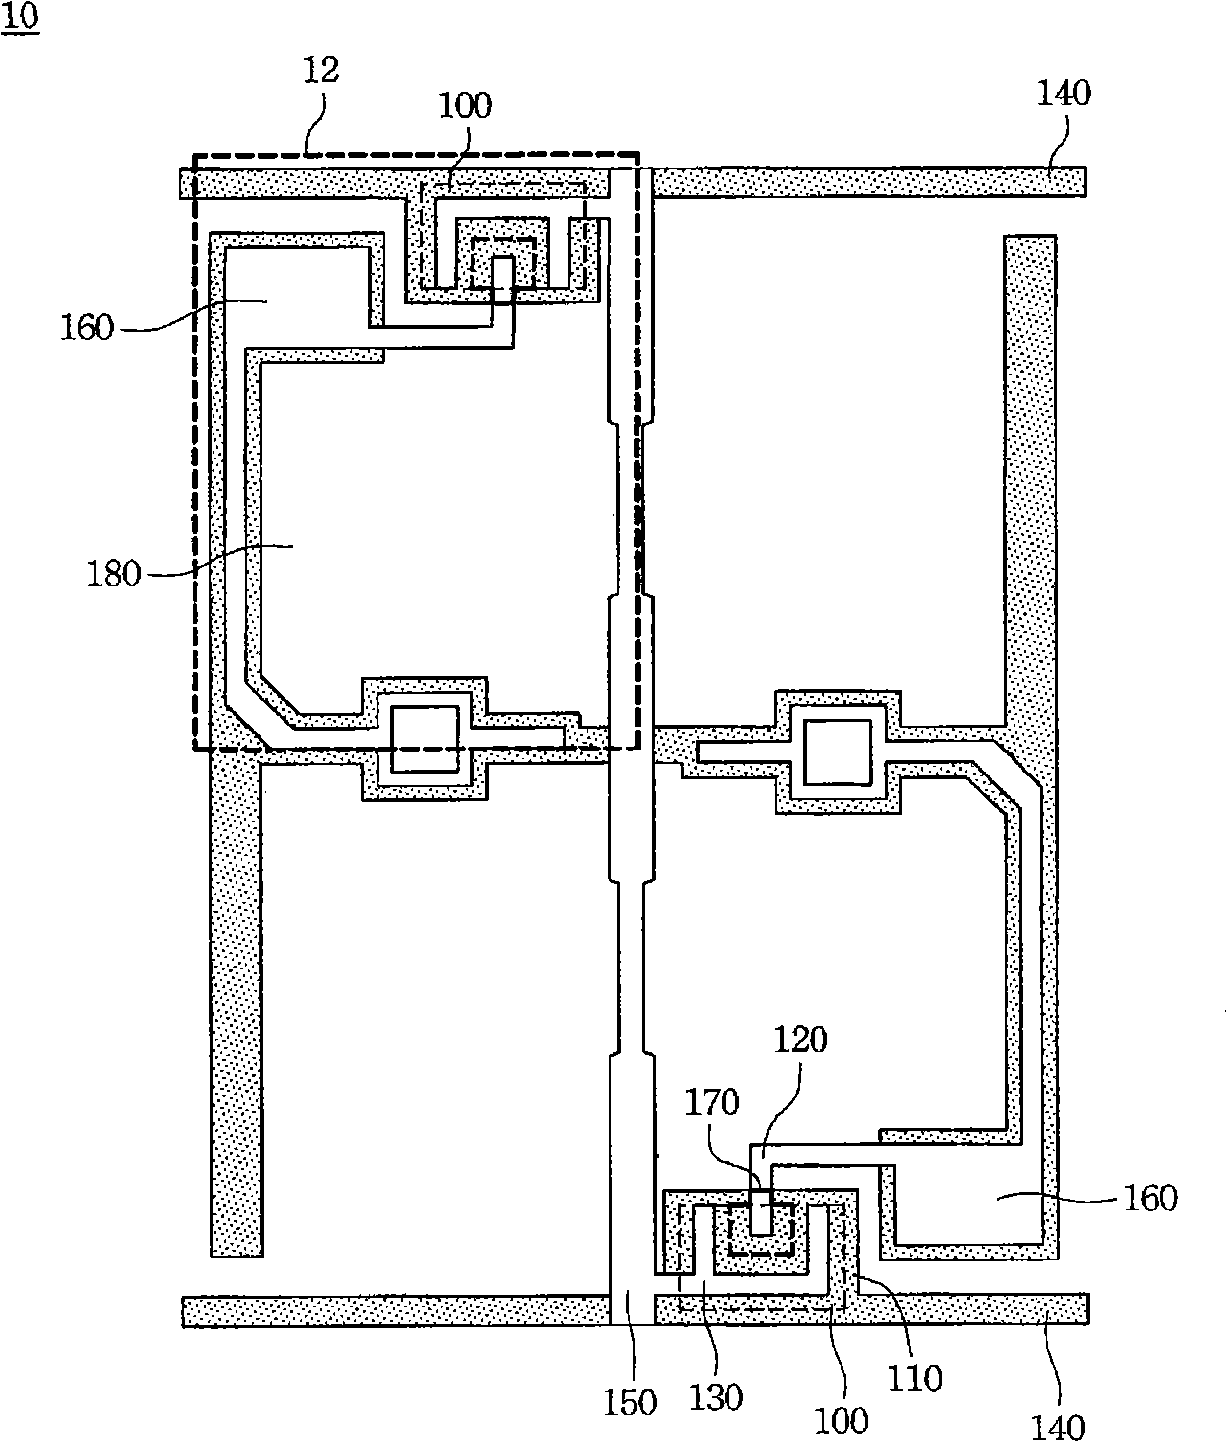
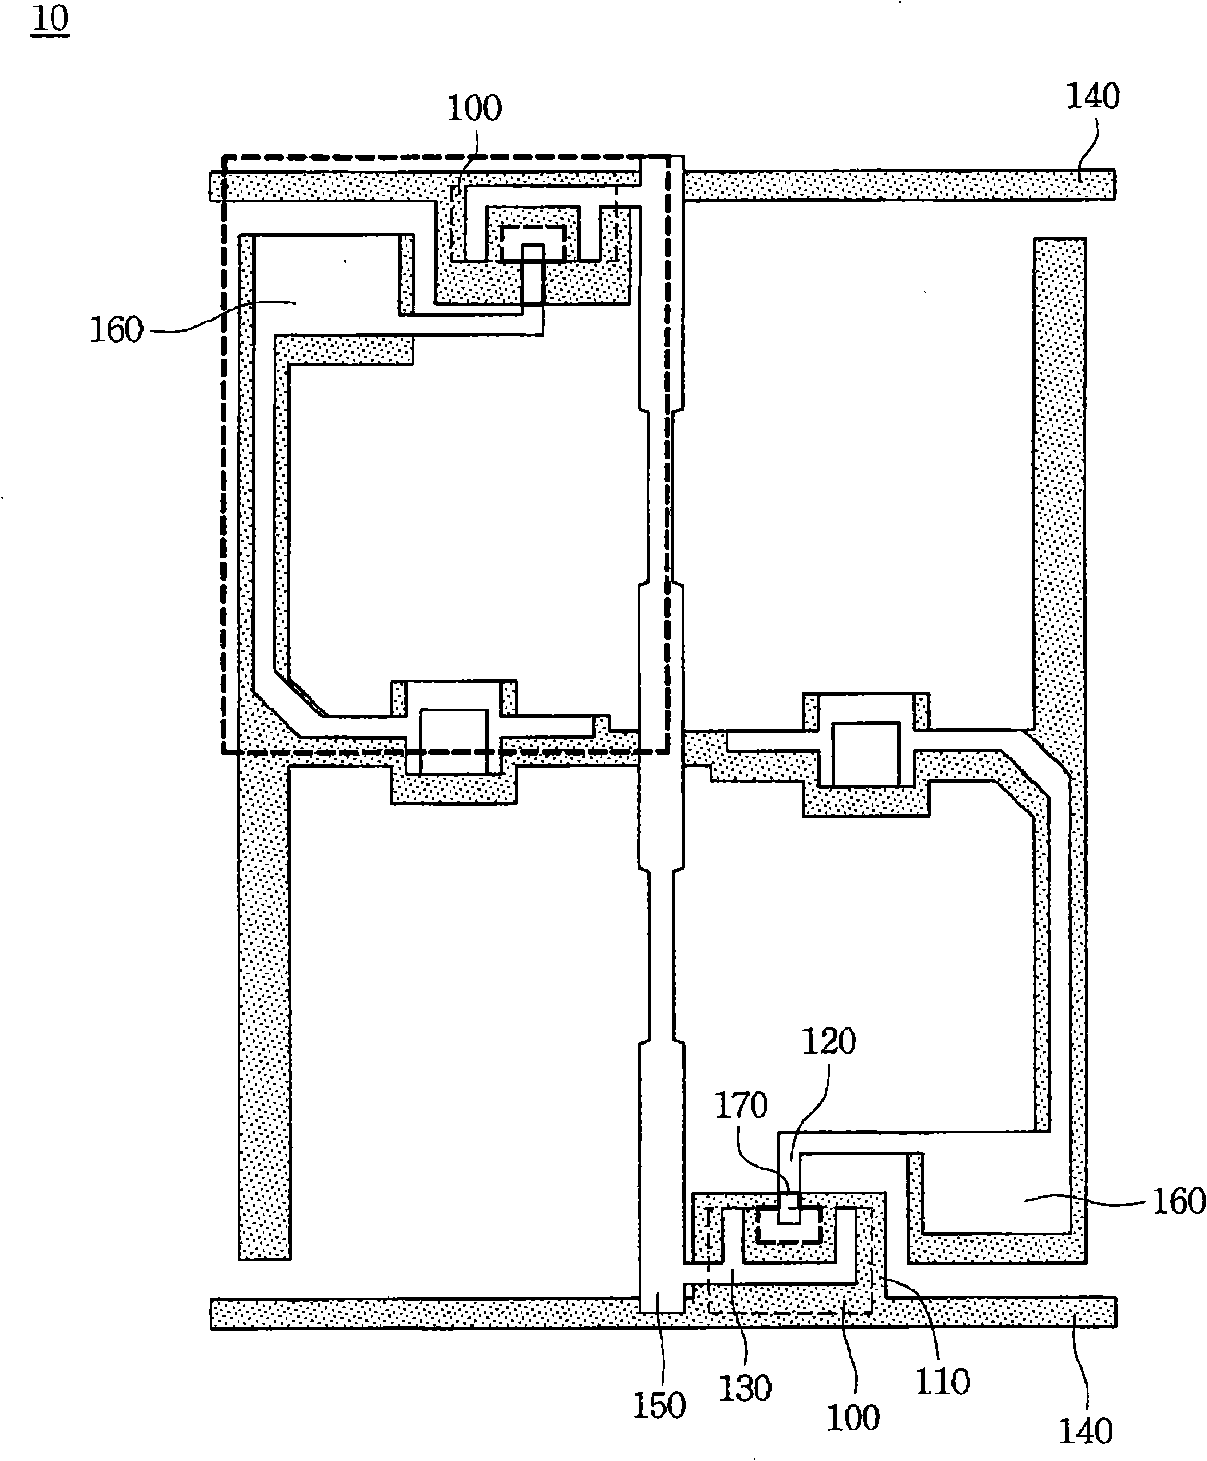
The invention discloses a pixel structure and a thin-film transistor. A grid connecting scanning line of the thin-film transistor is arranged at one surface of an insulating layer, and a semiconductor layer, a source electrode and a drain electrode are arranged at the other surface of the insulating layer. The source electrode is connected with a data line and the semiconductor layer. The first branch of the drain electrode is connected with the semiconductor layer and is partially aligned and superposed with the grid so as to induce parasitic capacitance. The second branch and the first branch of the drain electrode extend in the same direction and perpendicularly go across from above the scanning line. The second branch is partially aligned and superposed with the scanning line so as to induce a first compensation capacitance. A compensation electrode is connected with the second branch and is partially vertically arranged above the scanning line so as to induce a second compensation capacitance. The width of the line of compensation electrode is the total of the widths of the lines of first and second branches, so that the total of the parasitic capacitance, the first compensation capacitance and the second compensation capacitance is constant. The invention provides a pixel structure and a thin-film transistor and can solve the problem of uneven feed-through voltage due to displacement deviation of the two metal layers.
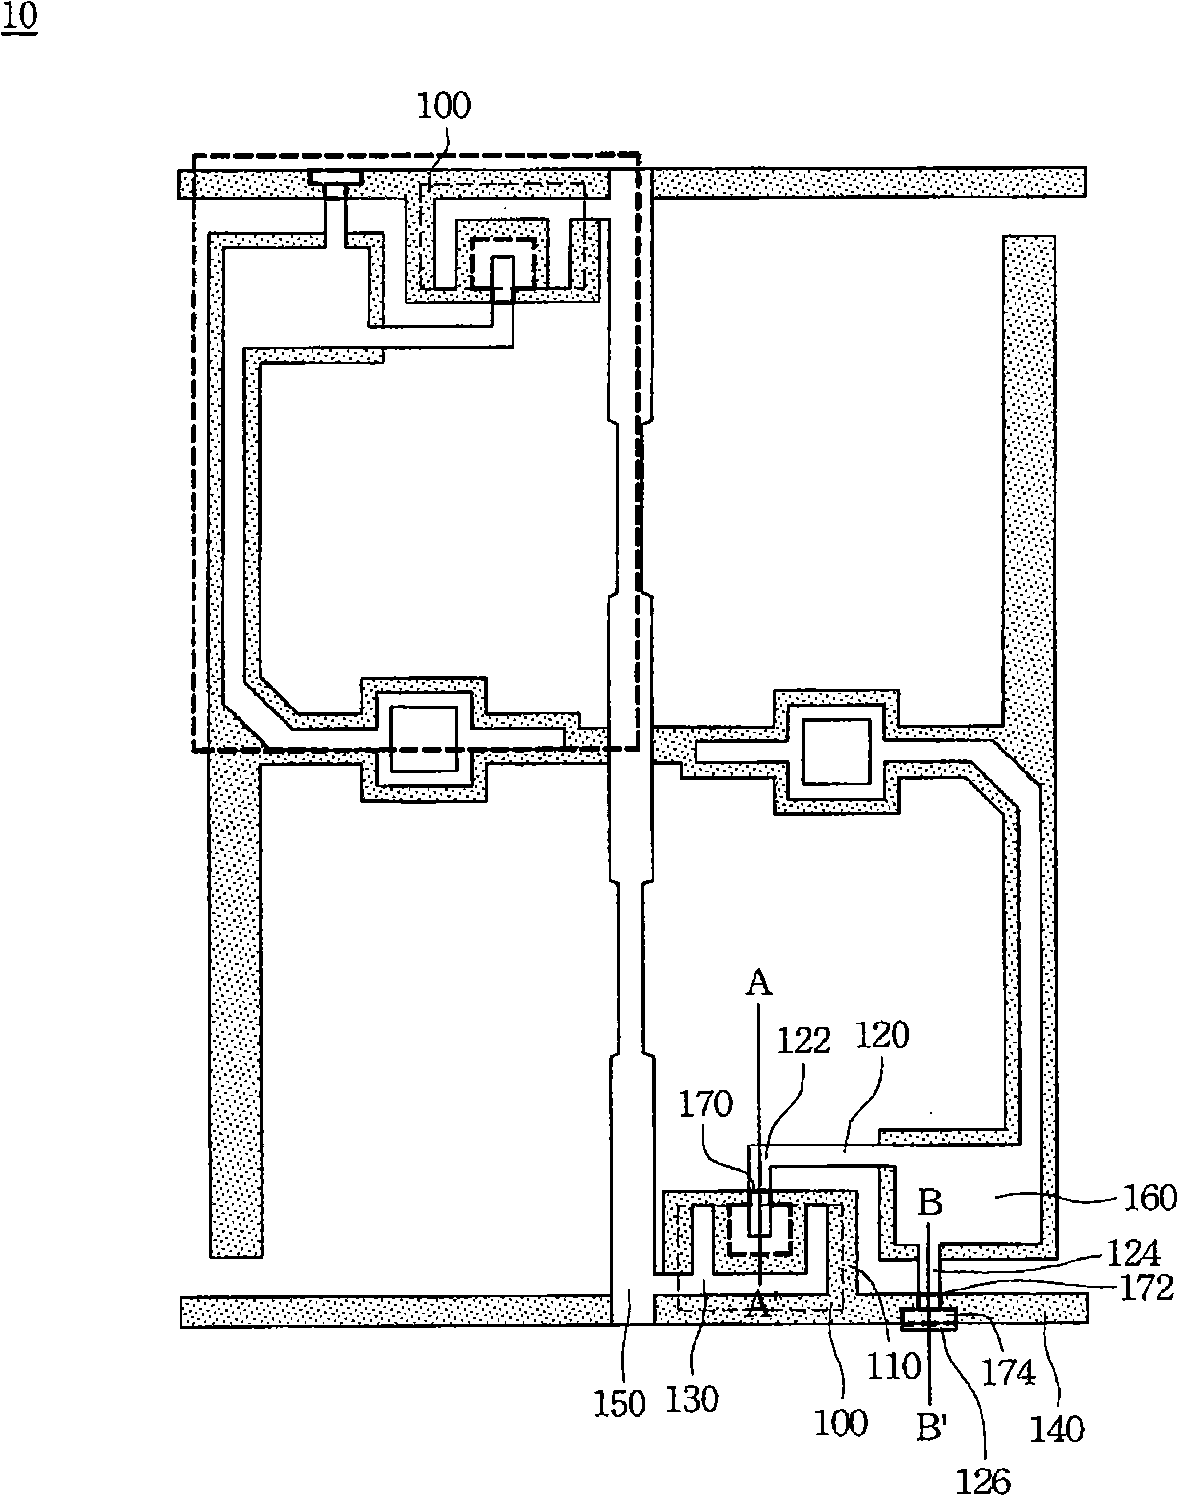
Owner:AU OPTRONICS CORP
Compensation type helix microstrip resonant unit and branch line coupler
The invention discloses a compensation type spiral microstrip resonance unit which includes an input port, an output port, a spiral microstrip line and a central microstrip line, wherein the spiral microstrip line is symmetrically disposed taking the central microstrip line as symmetrical line, and the spiral microstrip line is led out from the center of the central microstrip line and is a spiral microstrip open circuit line, one end of which is folded inwards; the invention further includes a long annular belt shaped open circuit compensation microstrip line and a short annular belt shaped open circuit compensation microstrip line which are led from the center of the central microstrip line, and which are disposed at the same side of the central microstrip line. The invention further discloses a branch-line coupler based on the compensation type spiral microstrip resonance unit. The resonance unit is transmission line at fundamental frequency, and has strong restraining effect on the transmitted signal at the second order and the third order harmonic position. The branch-line coupler comprised by the compensation type spiral microstrip resonance unit has advantages of harmonic suppression, small circuit area, low insertion loss and so on.
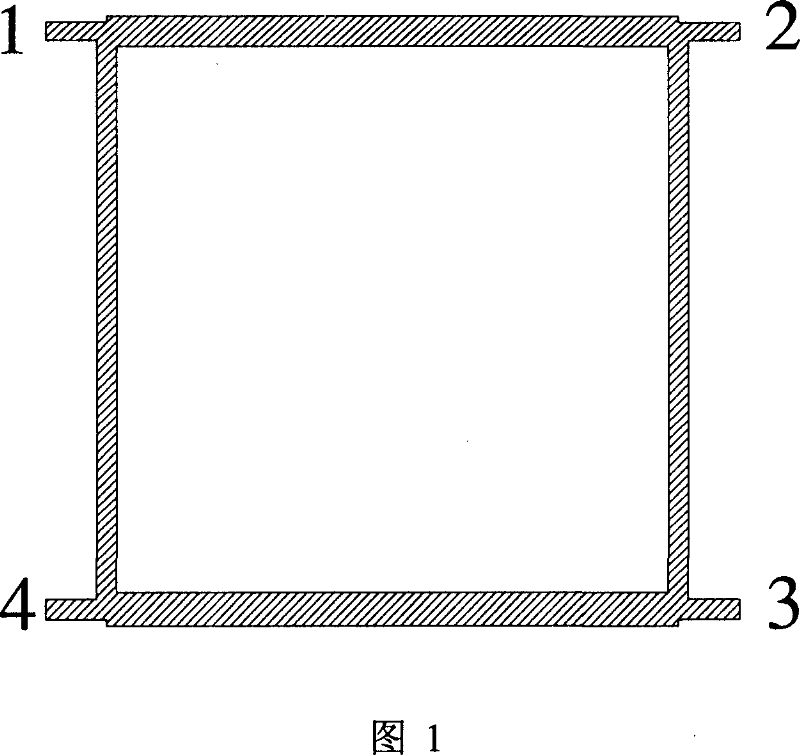
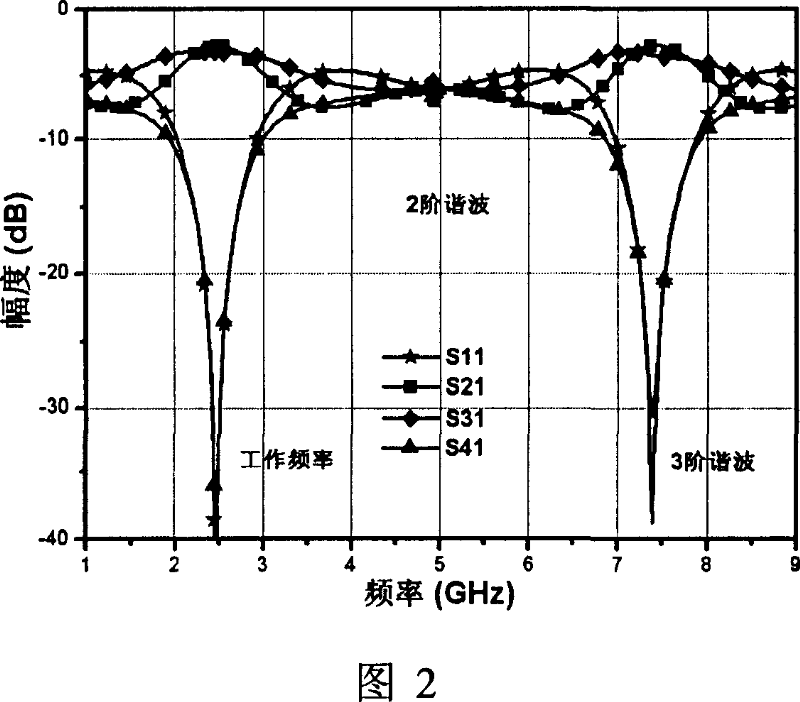
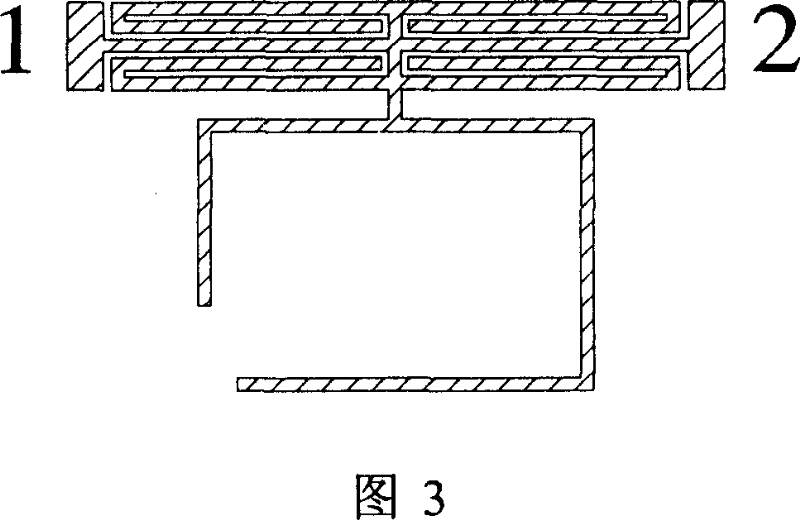
Owner:SHANGHAI INST OF MICROSYSTEM & INFORMATION TECH CHINESE ACAD OF SCI
Low temperature and low noise factor amplifying circuit
The invention is a low-temperature extremely low-noise coefficient amplifying circuit and its character: it adopts microband mixing circuit, adopts high-Q value spiral inductance coil and high-Q value capacitor in the input matching network in order to reduce input circuit loss and then noise; the spiral inductance coil's two ends adopts double parallel microbnd line structure, reducing parasitic parameters; the microband length of the negative feedback network is less than 1 / 10 working wavelength, reducing parasitic vibration; it adopts small resistances in input and output matching networks, enhancing value of real part of impedance; in the output matching network, the resistances in series with main lines and branch lines are proper to make the gain larger; the input and output matching networks is connected to 1 / 4 working wavelength branch lines, reducing circuit size to make the circuit able to work at low temperature for a long period. It can meet the requirements of low noise, larger gain, low standing wave ratio, working at low temperature for a long time, etc.
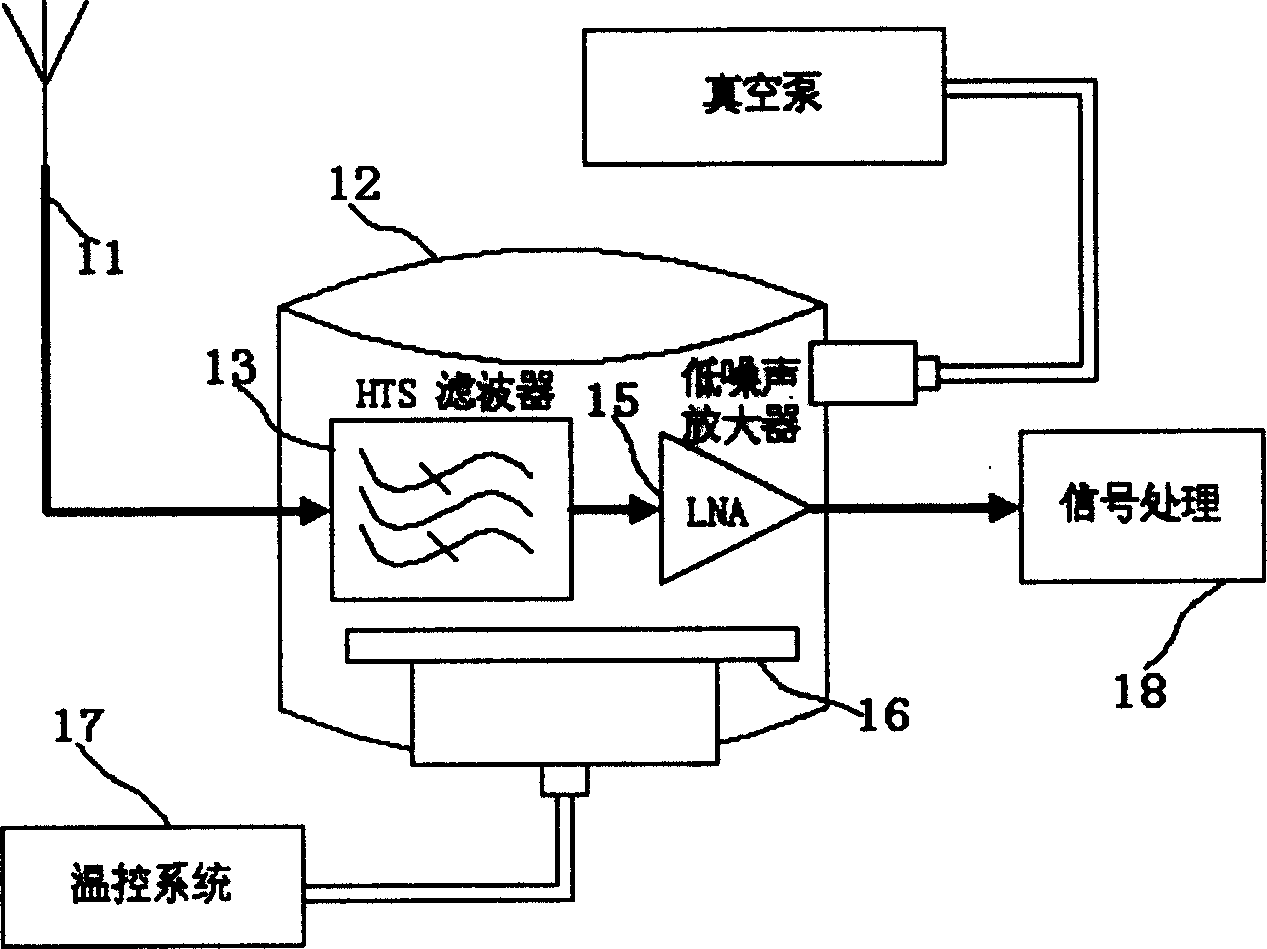
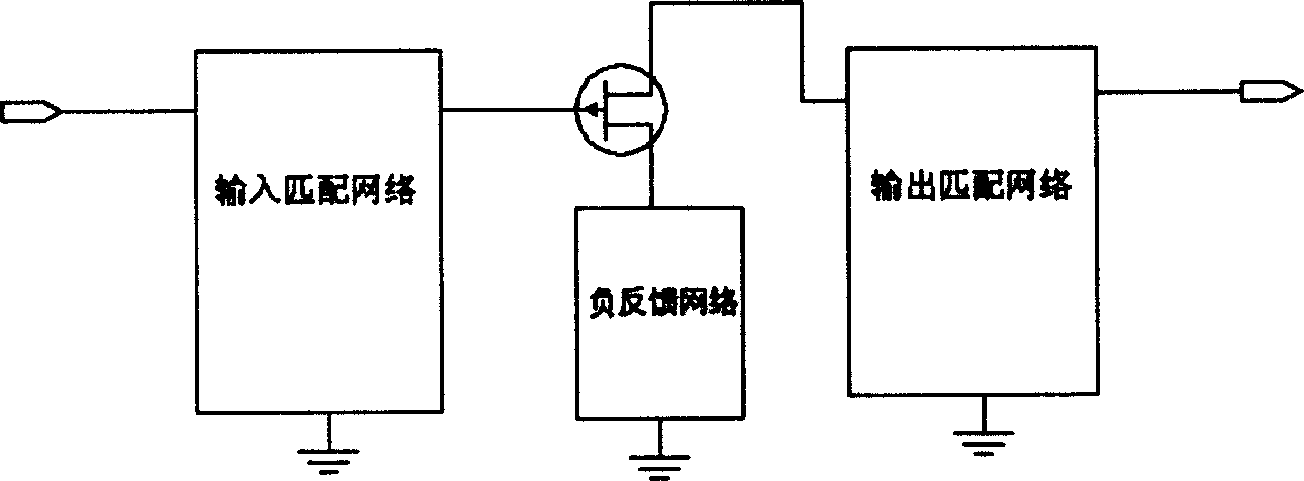
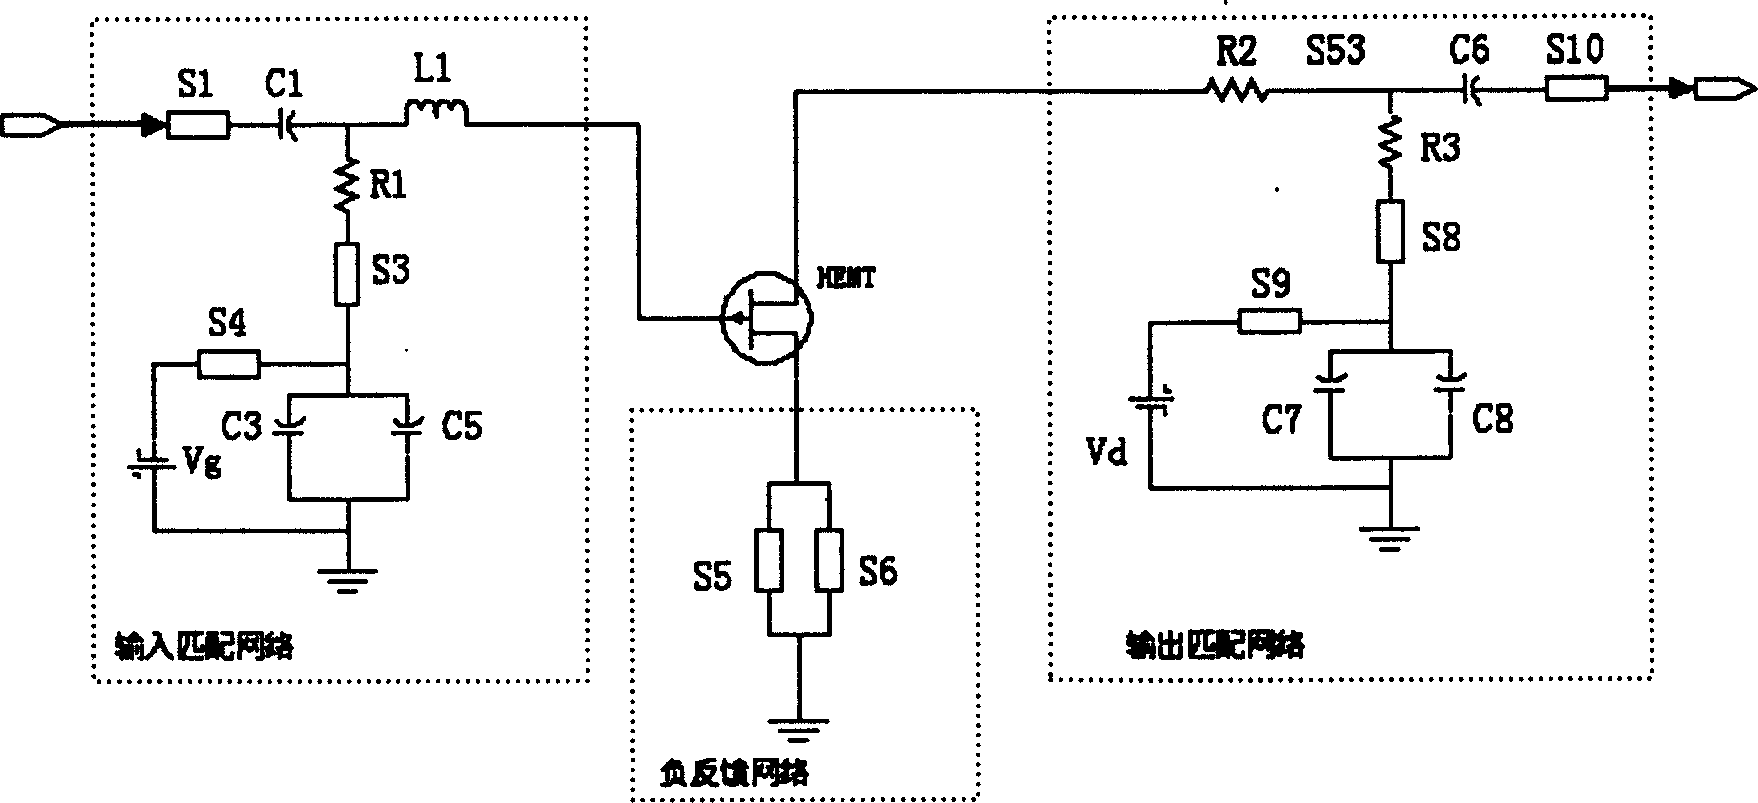
Owner:TSINGHUA UNIV
Multi-platform collaborative unmanned inspection task planning method and system for wind power scene
InactiveCN120469405AVehicle position/course/altitude controlPosition/direction controlUltra-widebandSpurline
The invention provides a multi-platform cooperative unmanned inspection task planning method and system for a wind power scene, and relates to the technical field of wind power plant inspection, and the method comprises the steps: based on a wind power plant three-dimensional scene model, adaptively dividing an inspection region, constructing a reachability path network, calculating an inspection difficulty coefficient according to target detection point information, and calculating a target inspection point; and generating an unmanned aerial vehicle and unmanned vehicle inspection area. A sensor is deployed to collect environment and equipment state data, feature vectors are extracted to establish an inspection constraint model, and main and branch inspection paths are planned on the reachability path network. And performing multi-platform relative positioning by using ultra-wideband radio waves, and dynamically optimizing an inspection path according to the equipment health score and the inspection constraint model. Through multi-platform cooperation, adaptive path planning and intelligent state identification, the wind power plant inspection efficiency and accuracy are improved, and the inspection cost is reduced.

Owner:STATE POWER INVESTMENT GRP FUCHENG DONGFANG NEW ENERGY POWER GENERATION CO LTD
Microwave filter
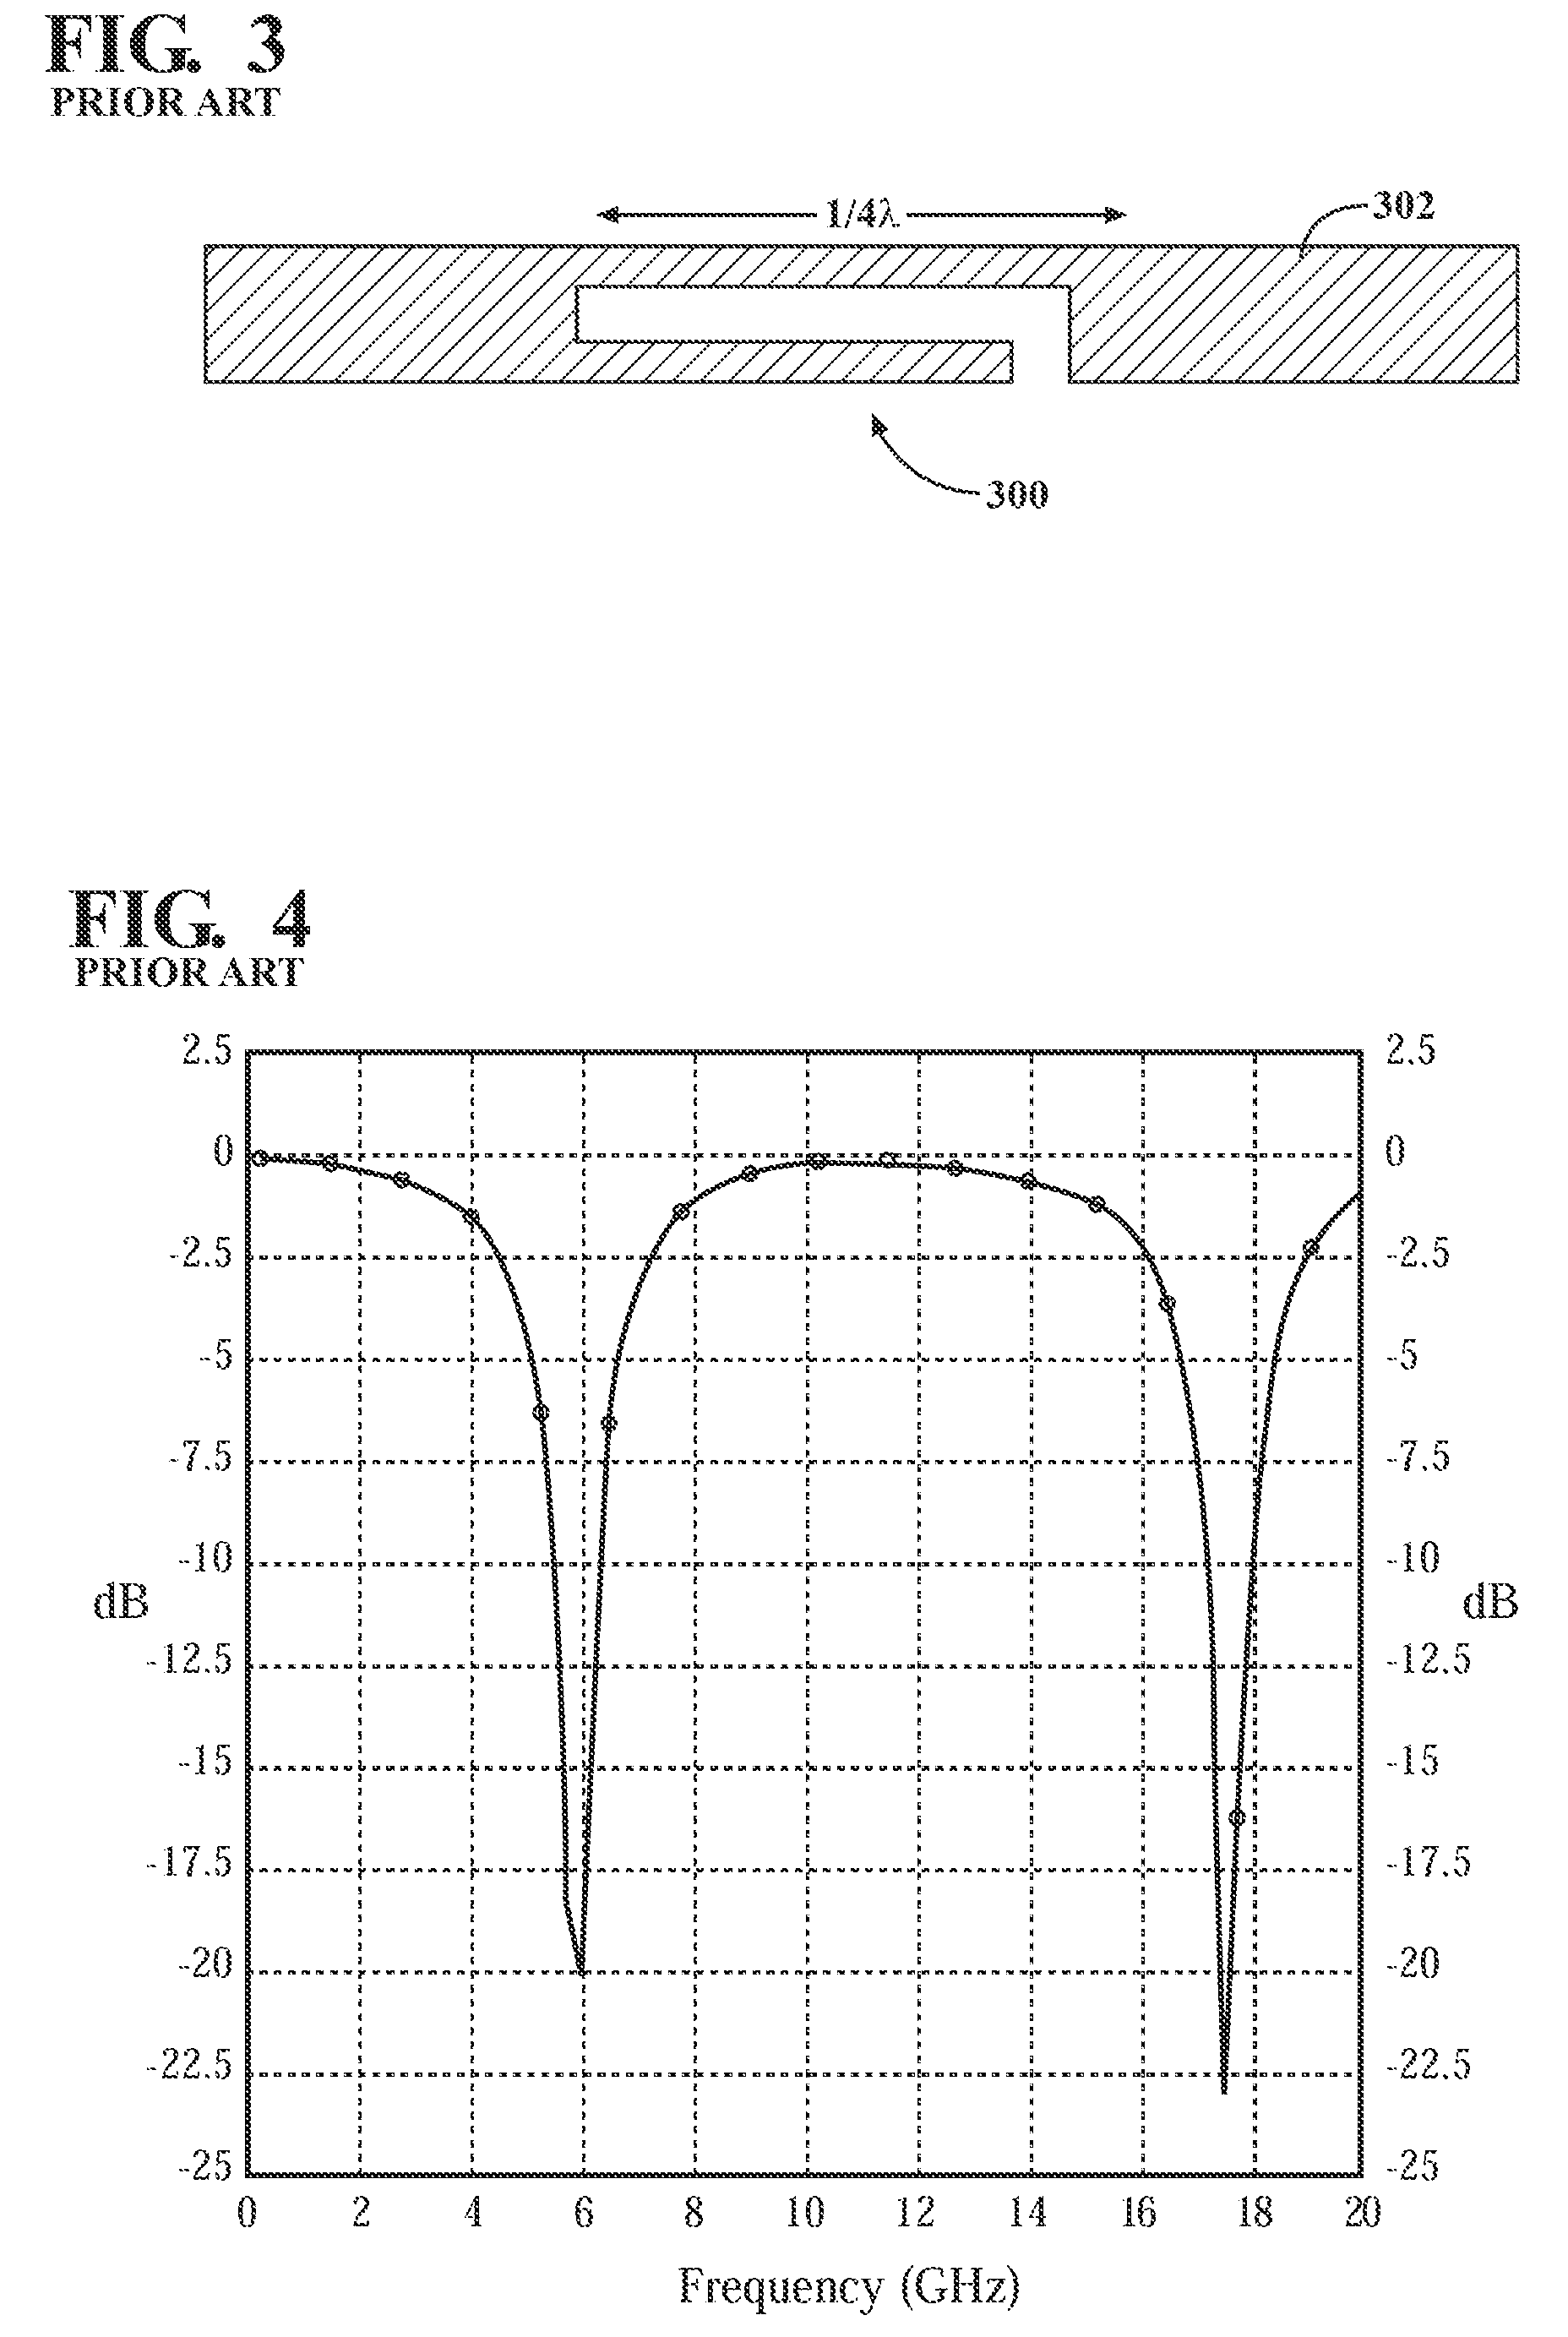
A microwave filter is provided that includes a transmission line having a signal input port and a signal output port, a stub connected to the transmission line between the input port and the output port, and a spurline embedded in the stub. The microwave filter is configured to substantially attenuate a frequency while substantially passing at least one predetermined odd harmonic of the frequency.
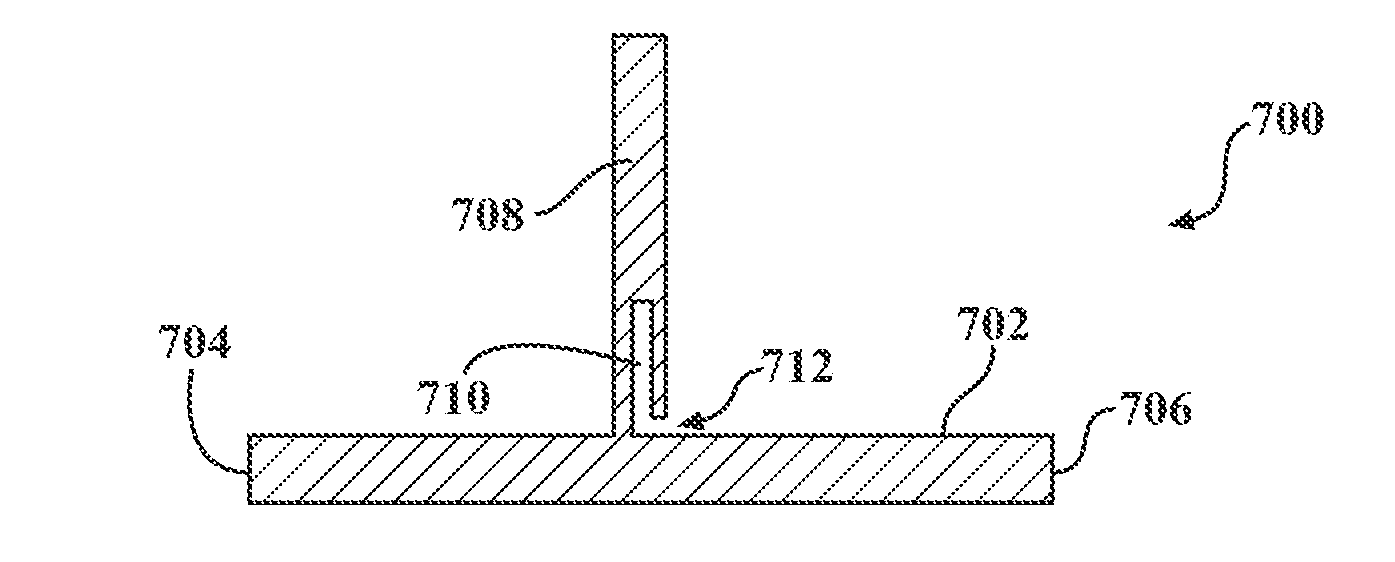
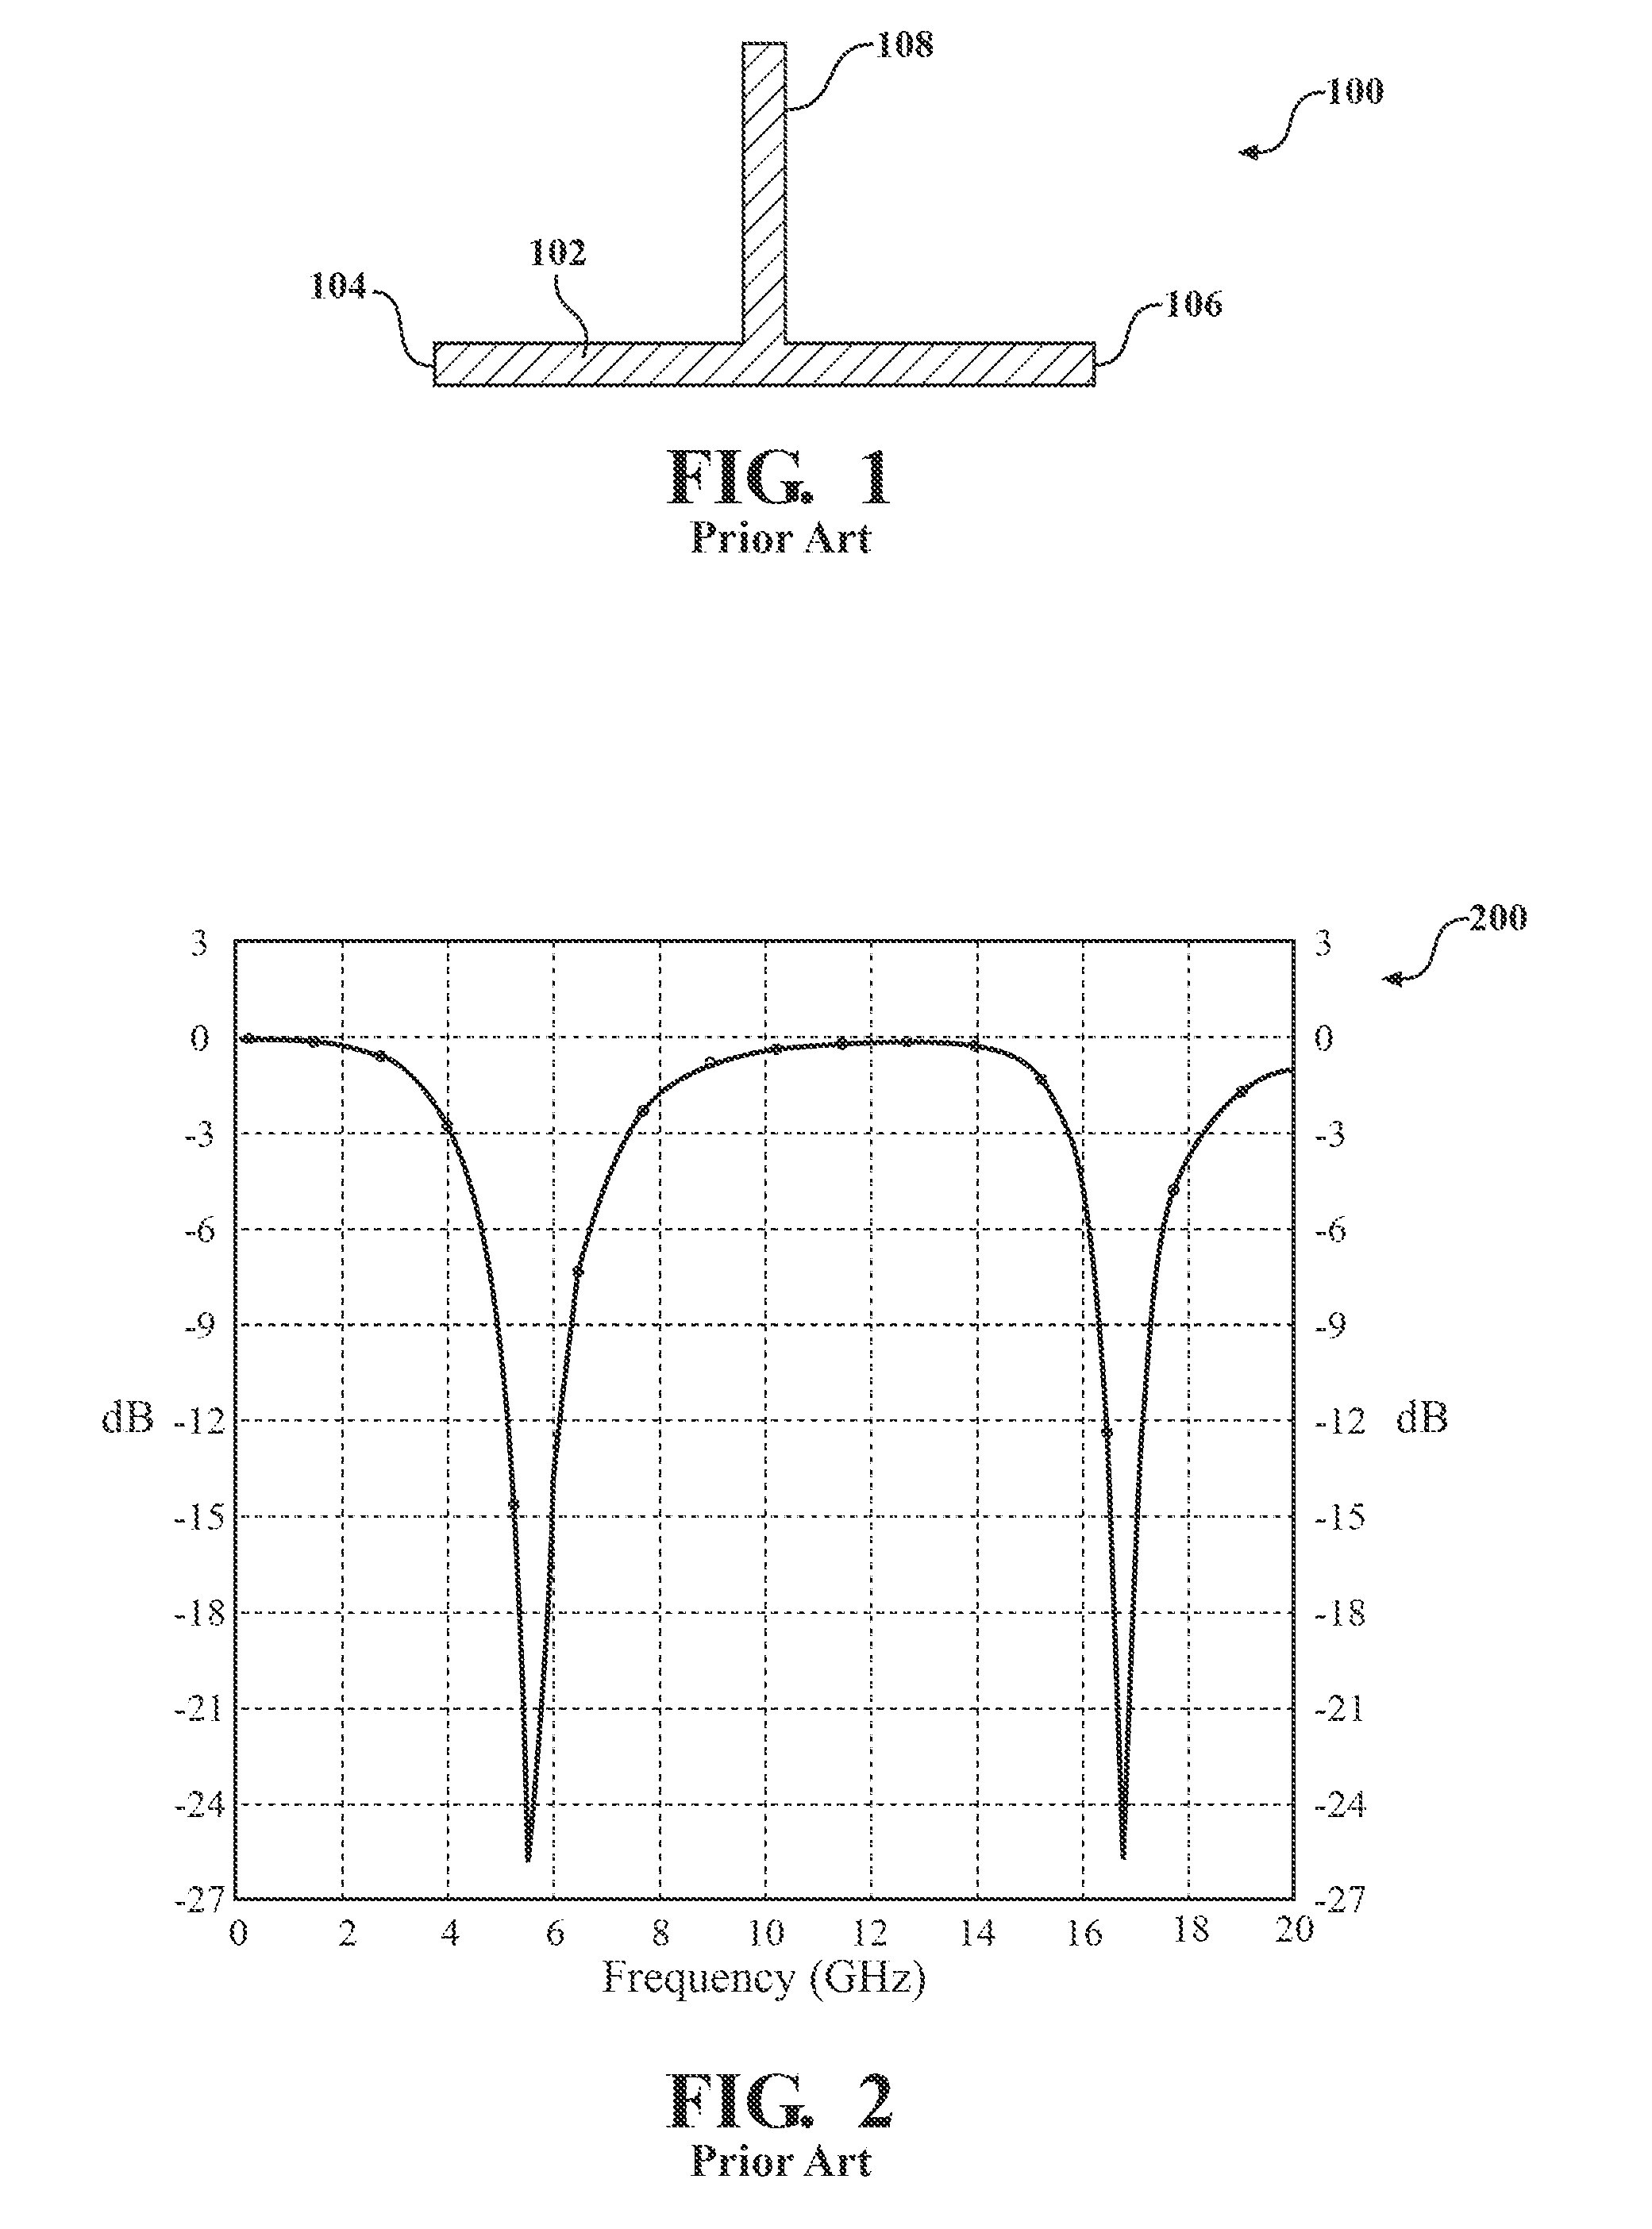
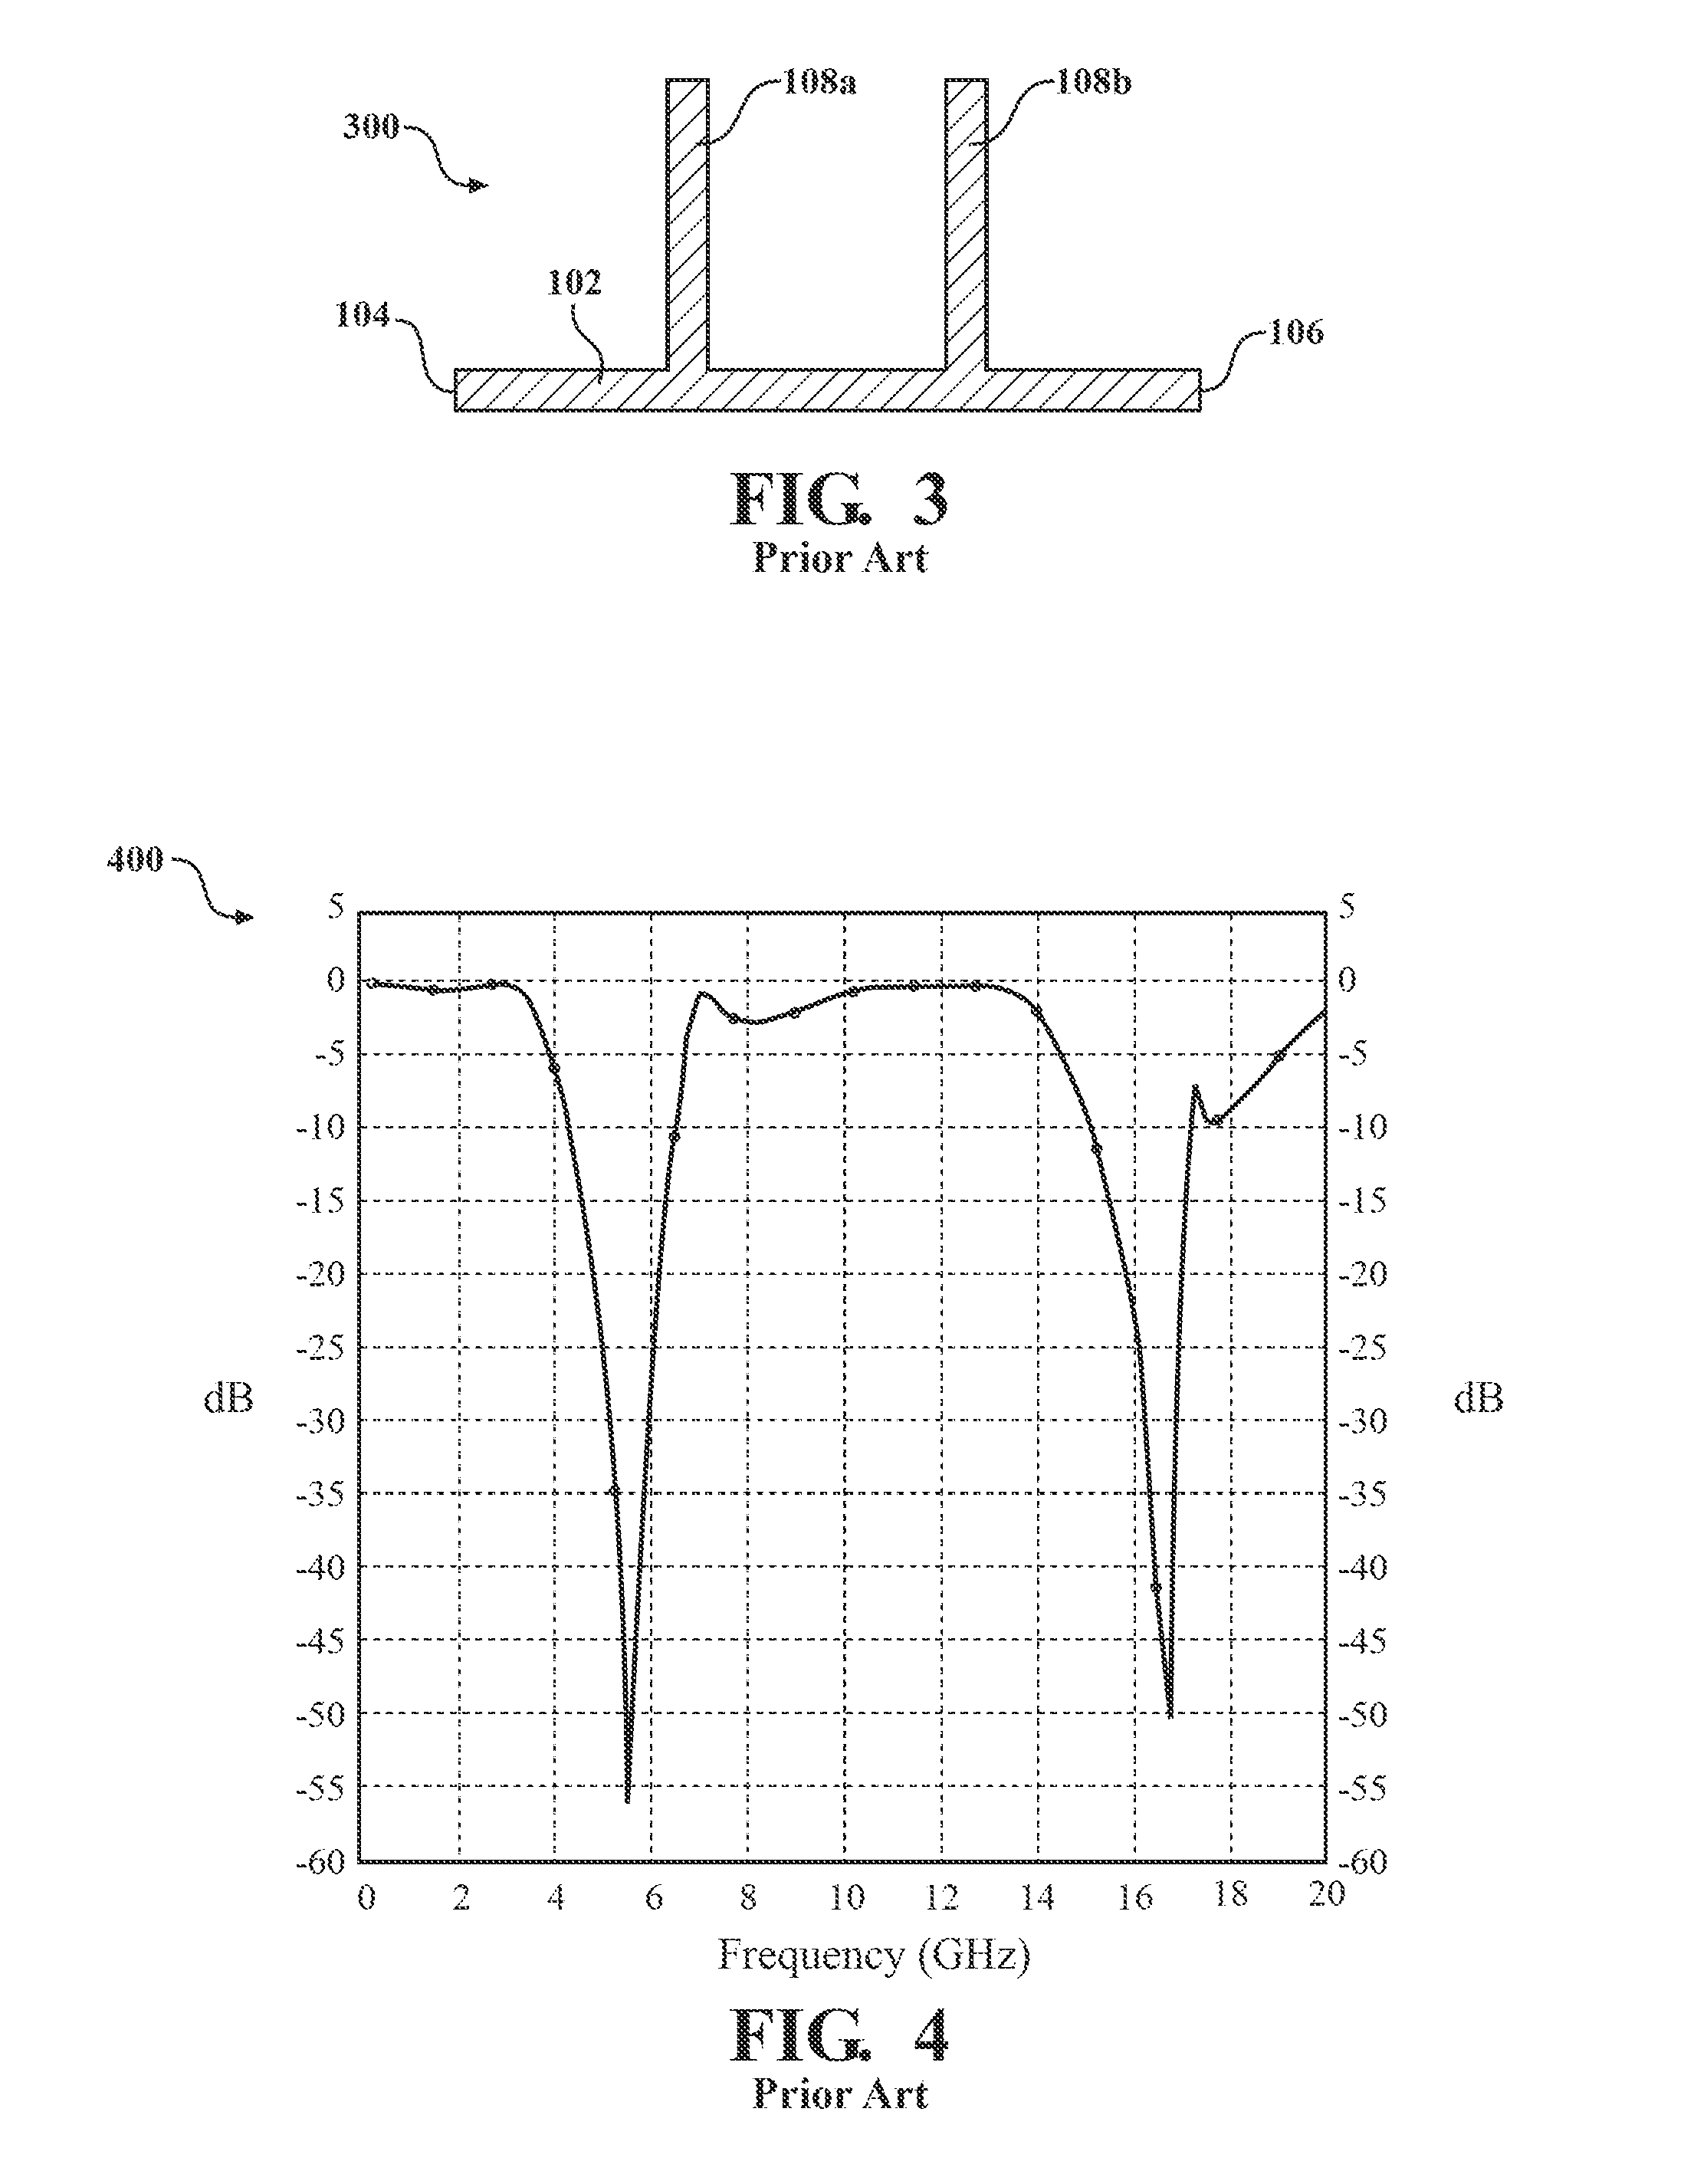
Owner:VALENTINE RES
Microstrip dual-passband coupling filter
The invention discloses a microstrip dual-passband coupling filter which comprises four feeder lines, two open branch lines and six microstrip lines, wherein six microstrip lines form a multi-mode dual-passband resonator for generating dual passband; the microstrip dual-passband coupling filter is of a bilaterally symmetrical structure; two sides of the multi-mode dual-passband resonator are respectively connected with one open branch line; the two open branch lines are respectively connected with the two feeder lines to form interdigital parallel coupled line structures; a connecting structure of the open branch lines and the multi-mode dual-passband resonator is a T-shaped structure; the two interdigital parallel coupled line structures are used as input and output respectively. The microstrip dual-passband coupling filter has high frequency selectivity and isolation, the two passbands can be adjusted independently, and the filter is simple in circuit structure and easy to process.
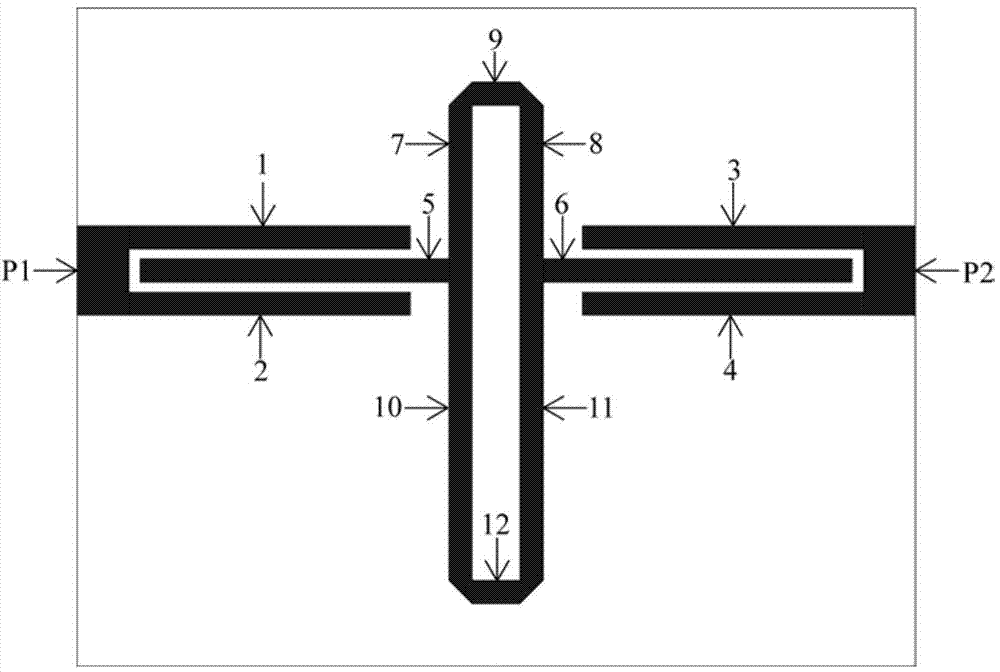
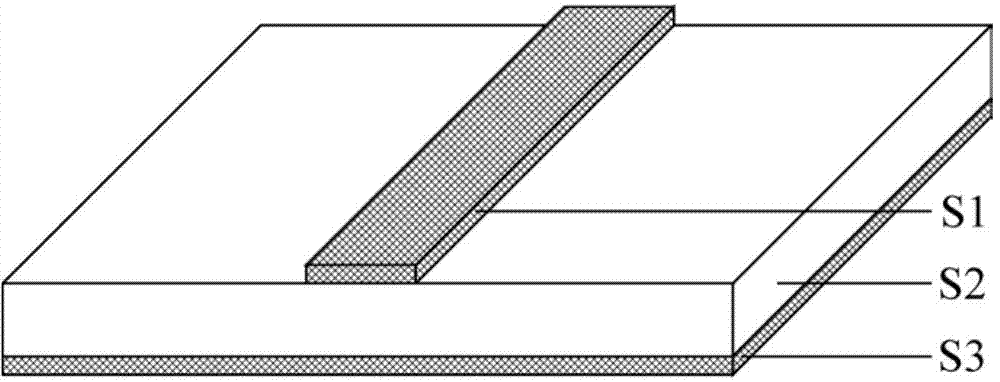
Owner:NANJING UNIV OF POSTS & TELECOMM
Double-dimension reconfigurable orthocoupler
InactiveCN106207361AContinuously adjustable center frequencyContinuously adjustable power ratioCoupling devicesSpurlineFrequency modulation
The invention discloses a double-dimension reconfigurable orthocoupler. The double-dimension reconfigurable orthocoupler comprises a dielectric plate, an improved branch coupler, a frequency modulation bias unit and a power-division-ratio adjusting bias unit, wherein the improved branch coupler adopts a matts structure and consists of a basic branch line coupler and crossed-shaped microstrip lines; the frequency modulation bias unit consists of four frequency modulation bias circuits; the power-division-ratio adjusting bias unit consists of two power-division-ratio adjusting bias circuits, wherein a first microwave signal is accessed to the input port of the basic branch line coupler; each frequency modulation bias circuit adjusts equivalent electrical lengths of series arms and parallel arms based on a first preset bias voltage and the first microwave signal; meanwhile, each frequency modulation bias circuit adjusts equivalent impendence of the parallel arms based on a second preset bias voltage and the first microwave signal; and the output port outputs a second microwave signal with a preset center frequency and preset power-division ratio. Based on the double-dimension reconfigurable orthocoupler, continuous adjustment of the center frequency and the power-division ratio is realized, and the purposes of reconfigurable center frequency and power-division ratio, signal quadrature output and easy processing are achieved.
Owner:GUANGDONG UNIV OF TECH
High-directivity spurline directional coupler
A spurline directional coupler includes a first coupling section and a second coupling section that are in parallel with each other for coupling, and a first sub-coupling section and a second sub-coupling section coupled with the first coupling section, and a third sub-coupling section and a fourth sub-coupling section coupled with the second coupling section. The parallel coupling relationship between the coupling section and the sub-coupling sections generates a capacitive effect thereby may improve isolation and directivity of the spurline directional coupler.
Owner:INTEGRATED SYST SOLUTION +1
Compact On-Chip Branchline Coupler Using Slow Wave Transmission Line
Branchline coupler structure using slow wave transmission line effect having both large inductance and large capacitance per unit length. The branchline coupler structure includes a plurality of quarter-wavelength transmission lines, at least one of which includes a high impedance arm and a low impedance arm. The high and low impedances are relative to each other. The high impedance arm includes a plurality of narrow cells and having an inductance of nL and a capacitance of C / n, and the low impedance arm includes a plurality of wide cells and having an inductance of L / n and capacitance of nC. The wide and narrow cells are relative to each other, and the wide and narrow cells are adjacent each other to form a signal layer having step discontinuous alternative widths.
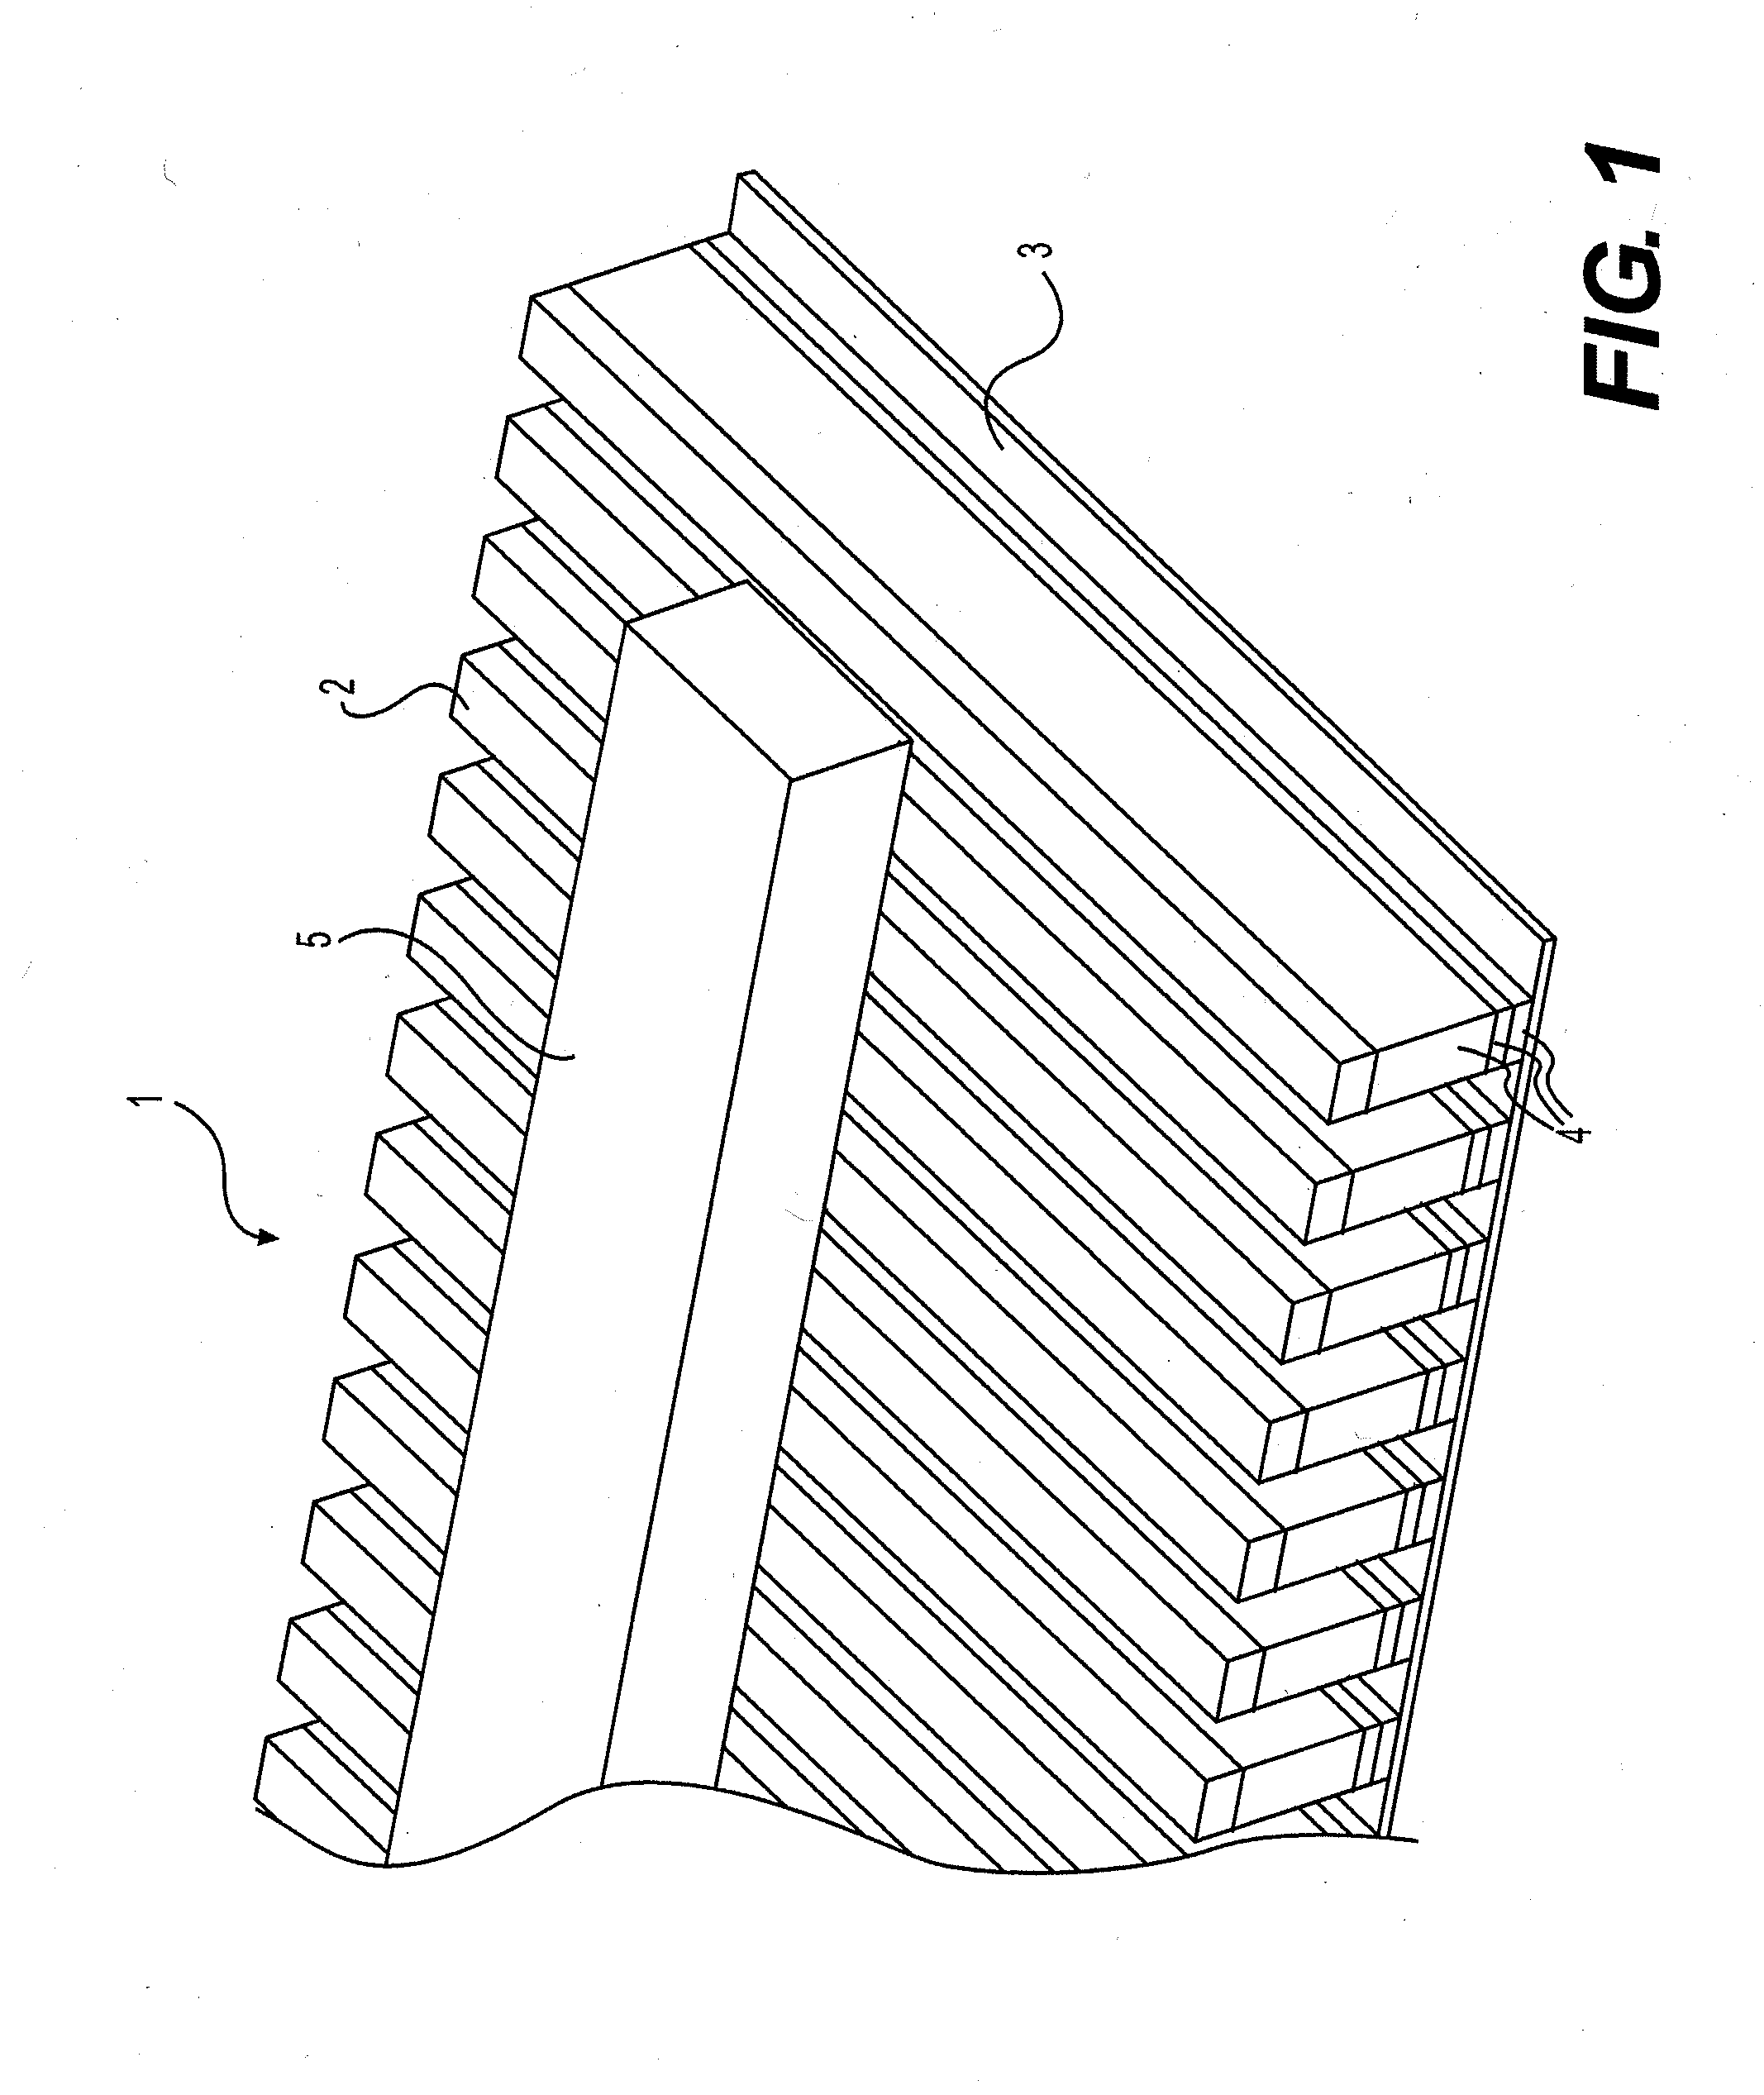
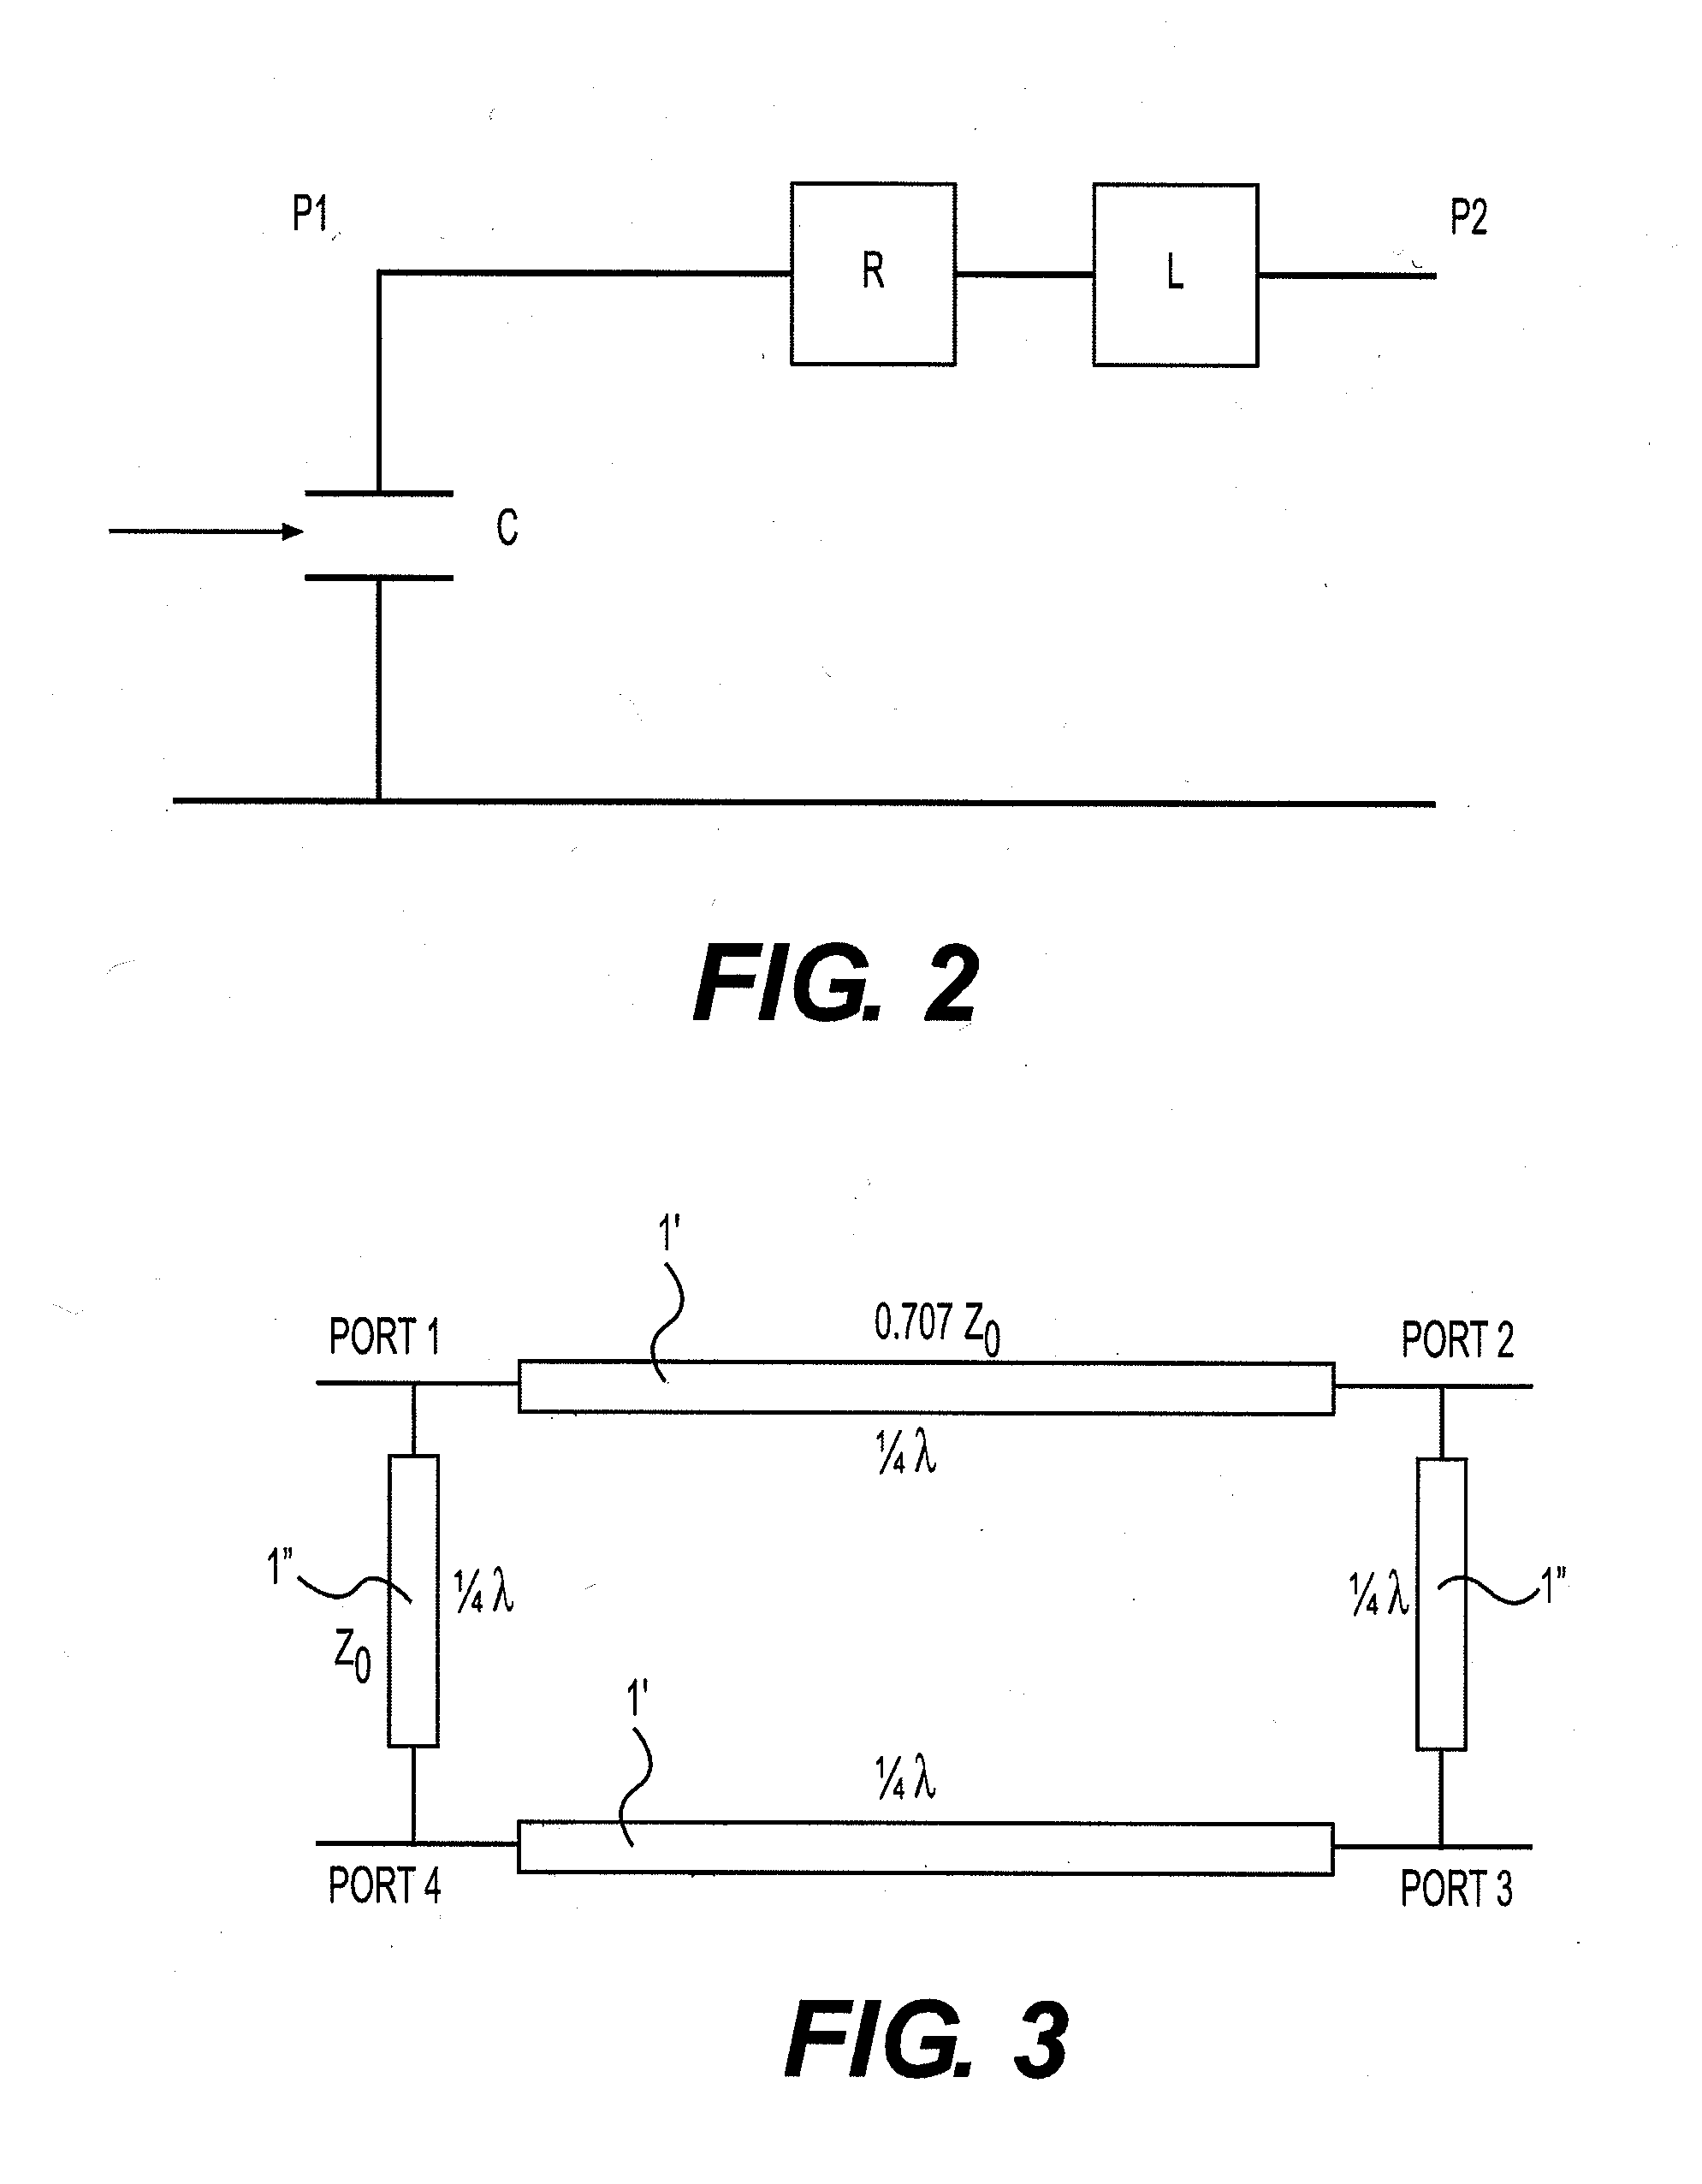
Owner:GLOBALFOUNDRIES US INC
Flexible broadband branch line coupler capable of suppressing triple harmonic waves
The invention relates to a flexible broadband branch line coupler capable of suppressing triple harmonic waves. The coupler can be applied to the scene having requirement for the bending performance of the branch line coupler. The bandwidth in the passband is wide and the insertion loss is low. Compared with the method of additionally arranging the filter to suppress the harmonic waves, the coupler is simple in structure and easy to design; besides, the defect ground is additionally arranged in the designed coupler so that high microstrip line width can be realized and processing and implementation are easy.
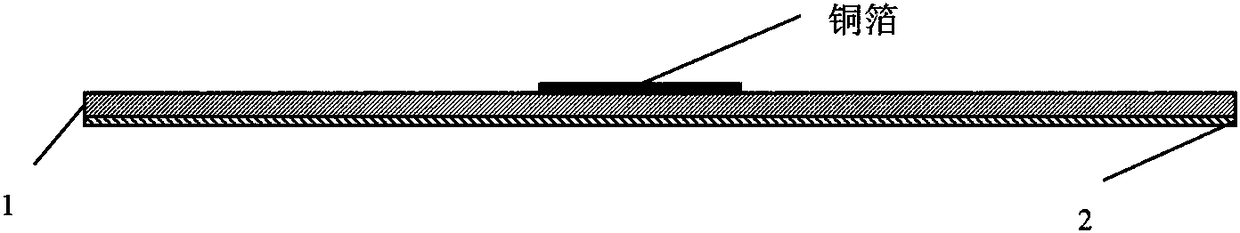
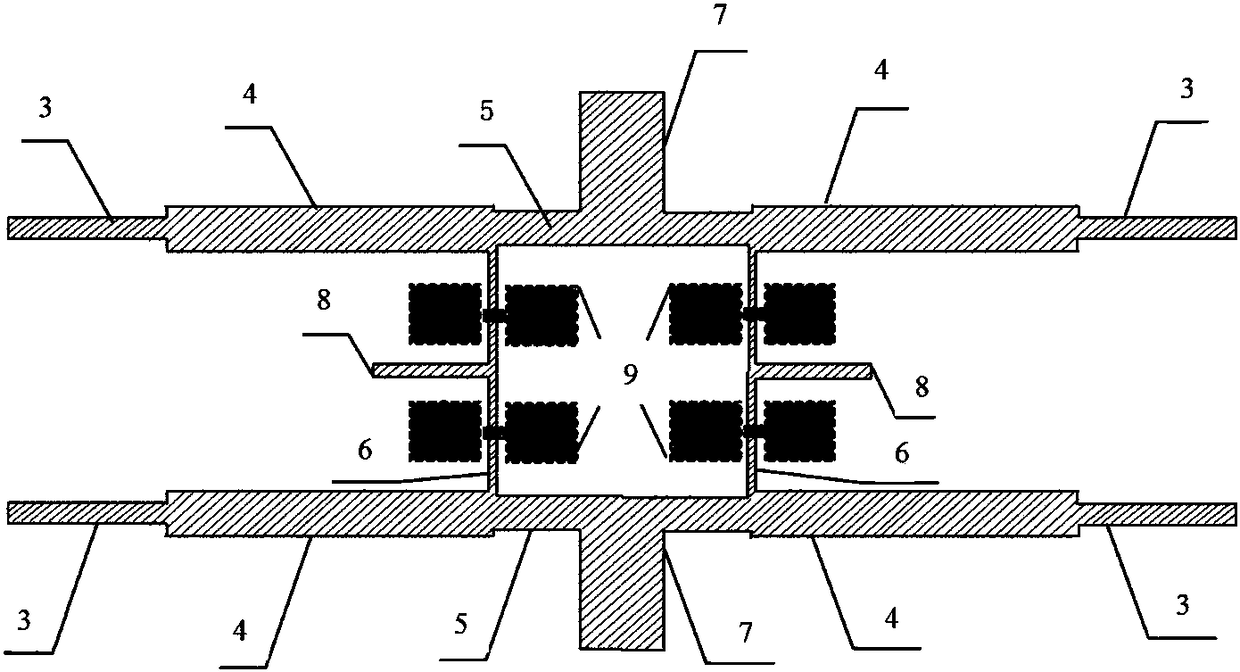
Owner:NANJING UNIV OF POSTS & TELECOMM +1
Asymmetrical bridge type DC/DC converter
InactiveCN1371160AHigh input applicationsImprove conversion efficiencyAc-dc conversionApparatus with intermediate ac conversionLinear controlNon symmetric
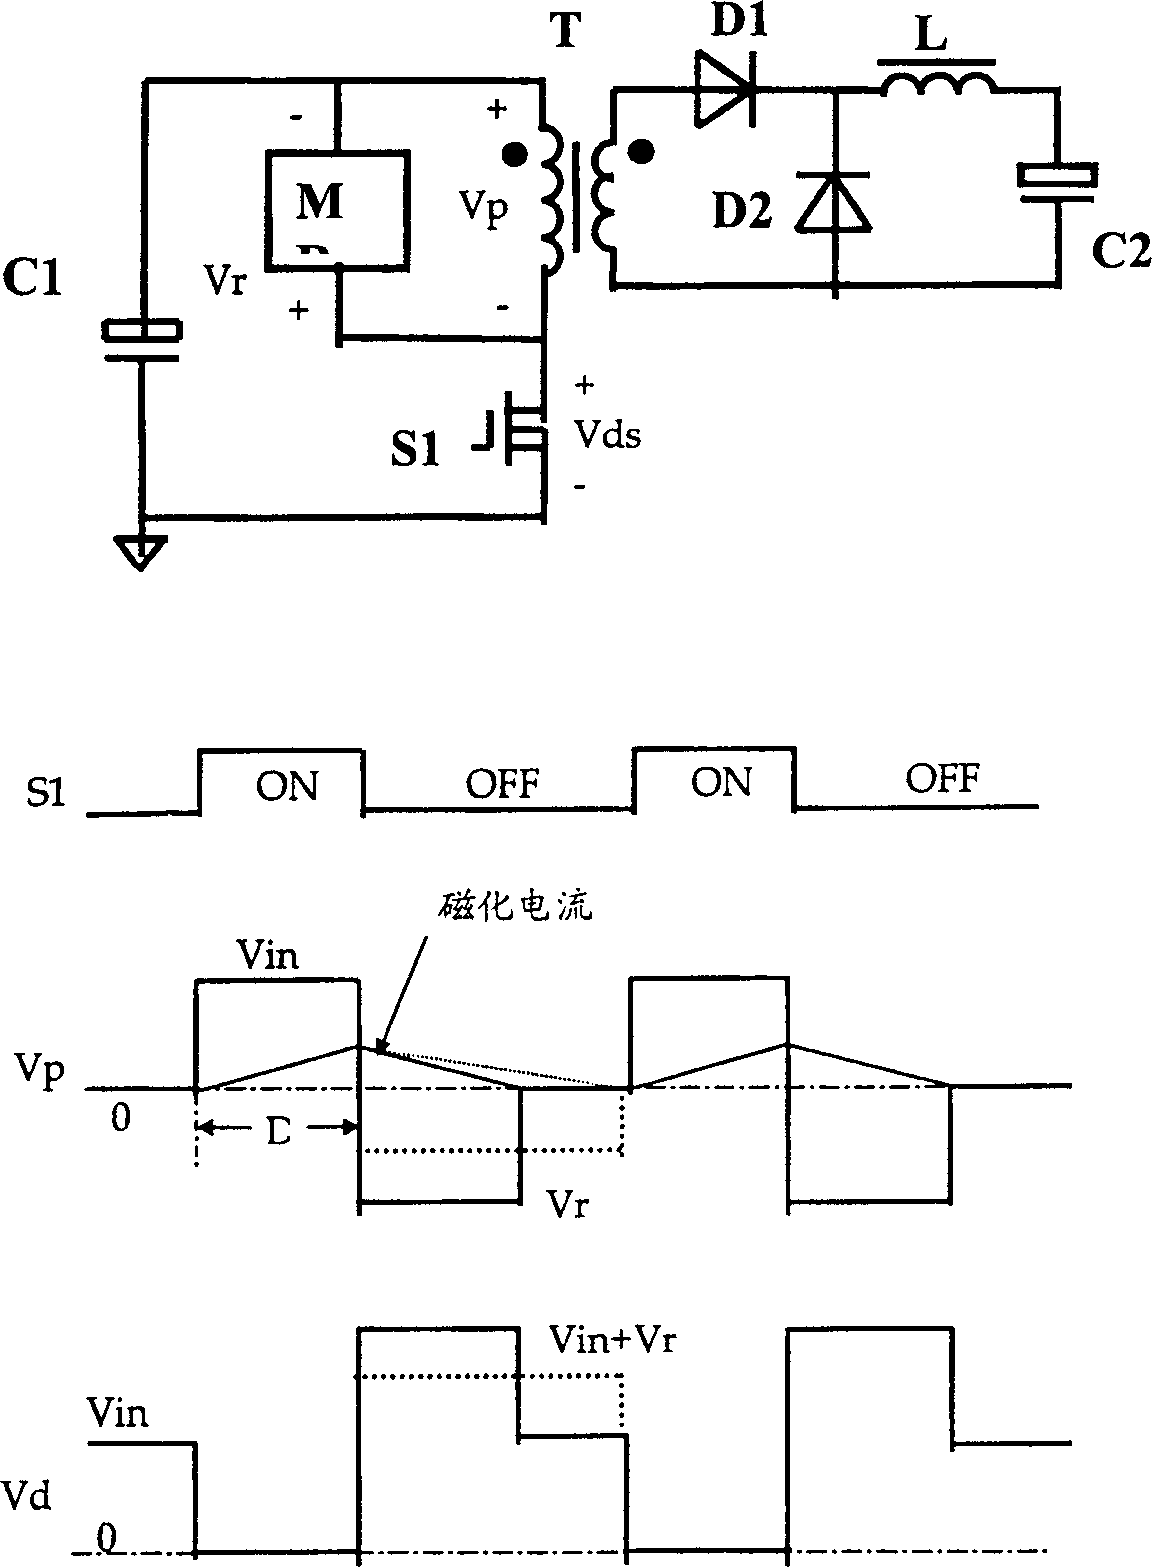
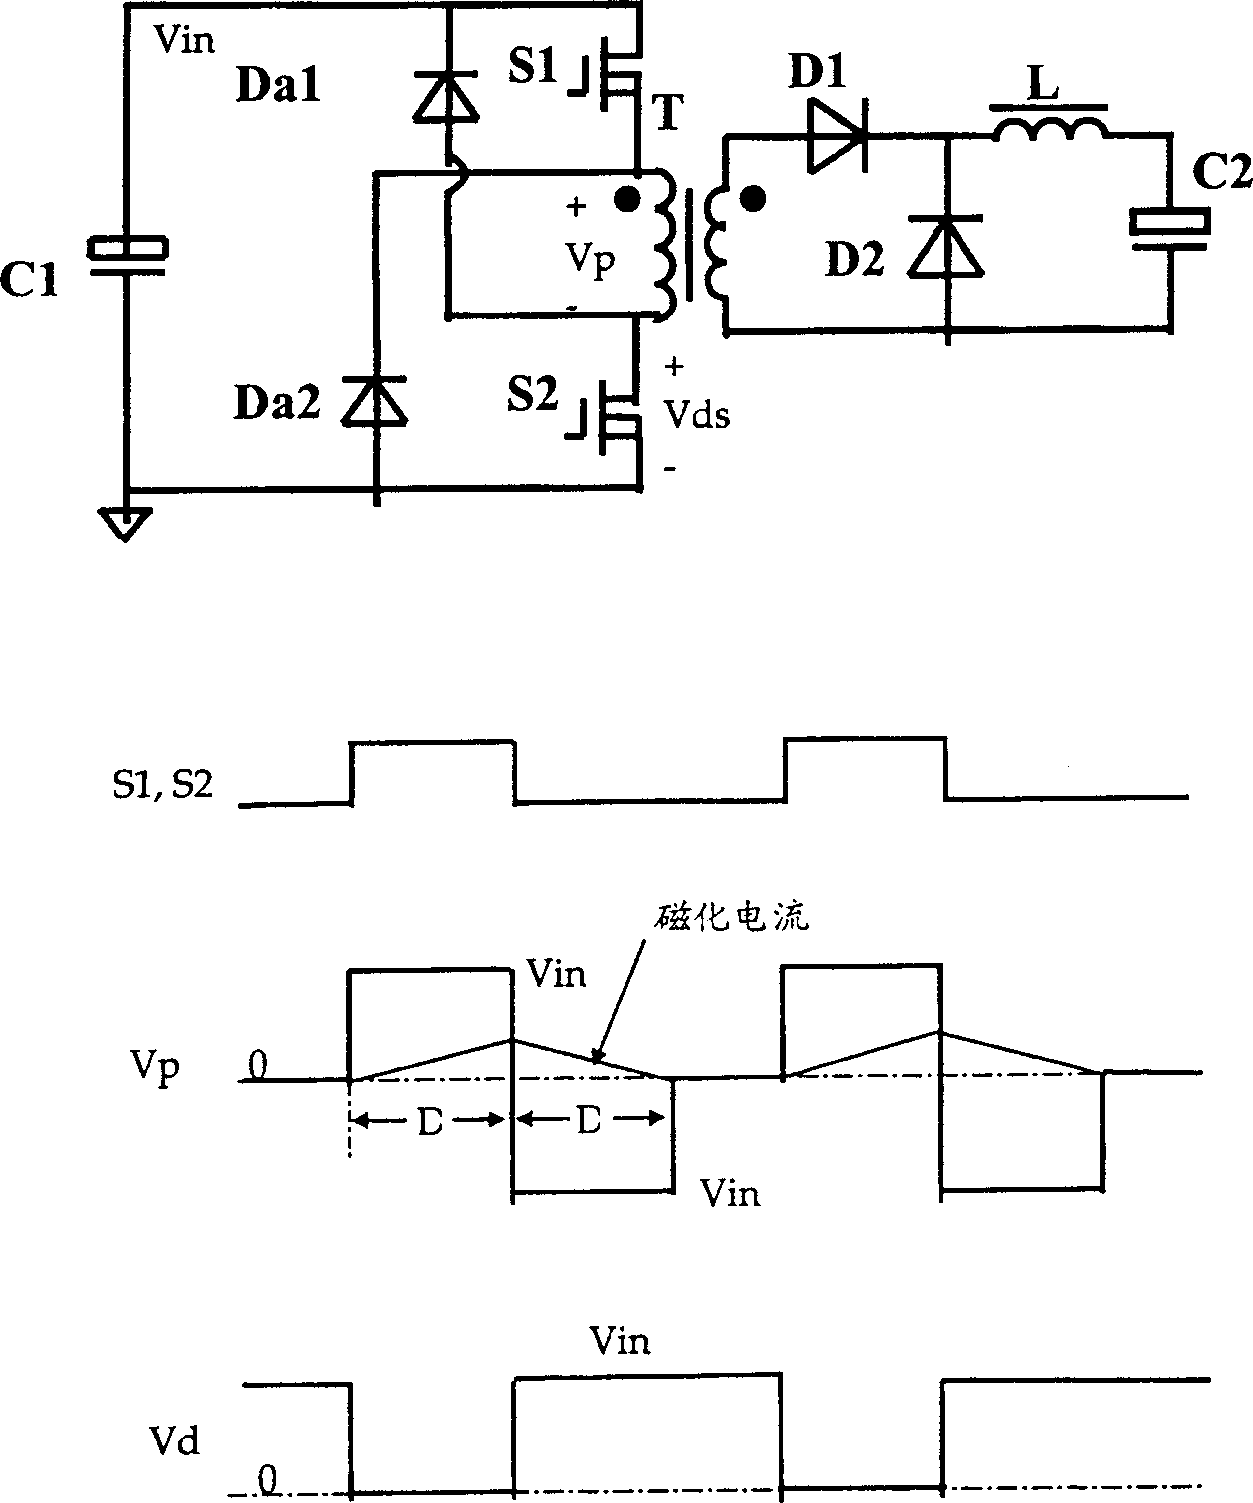
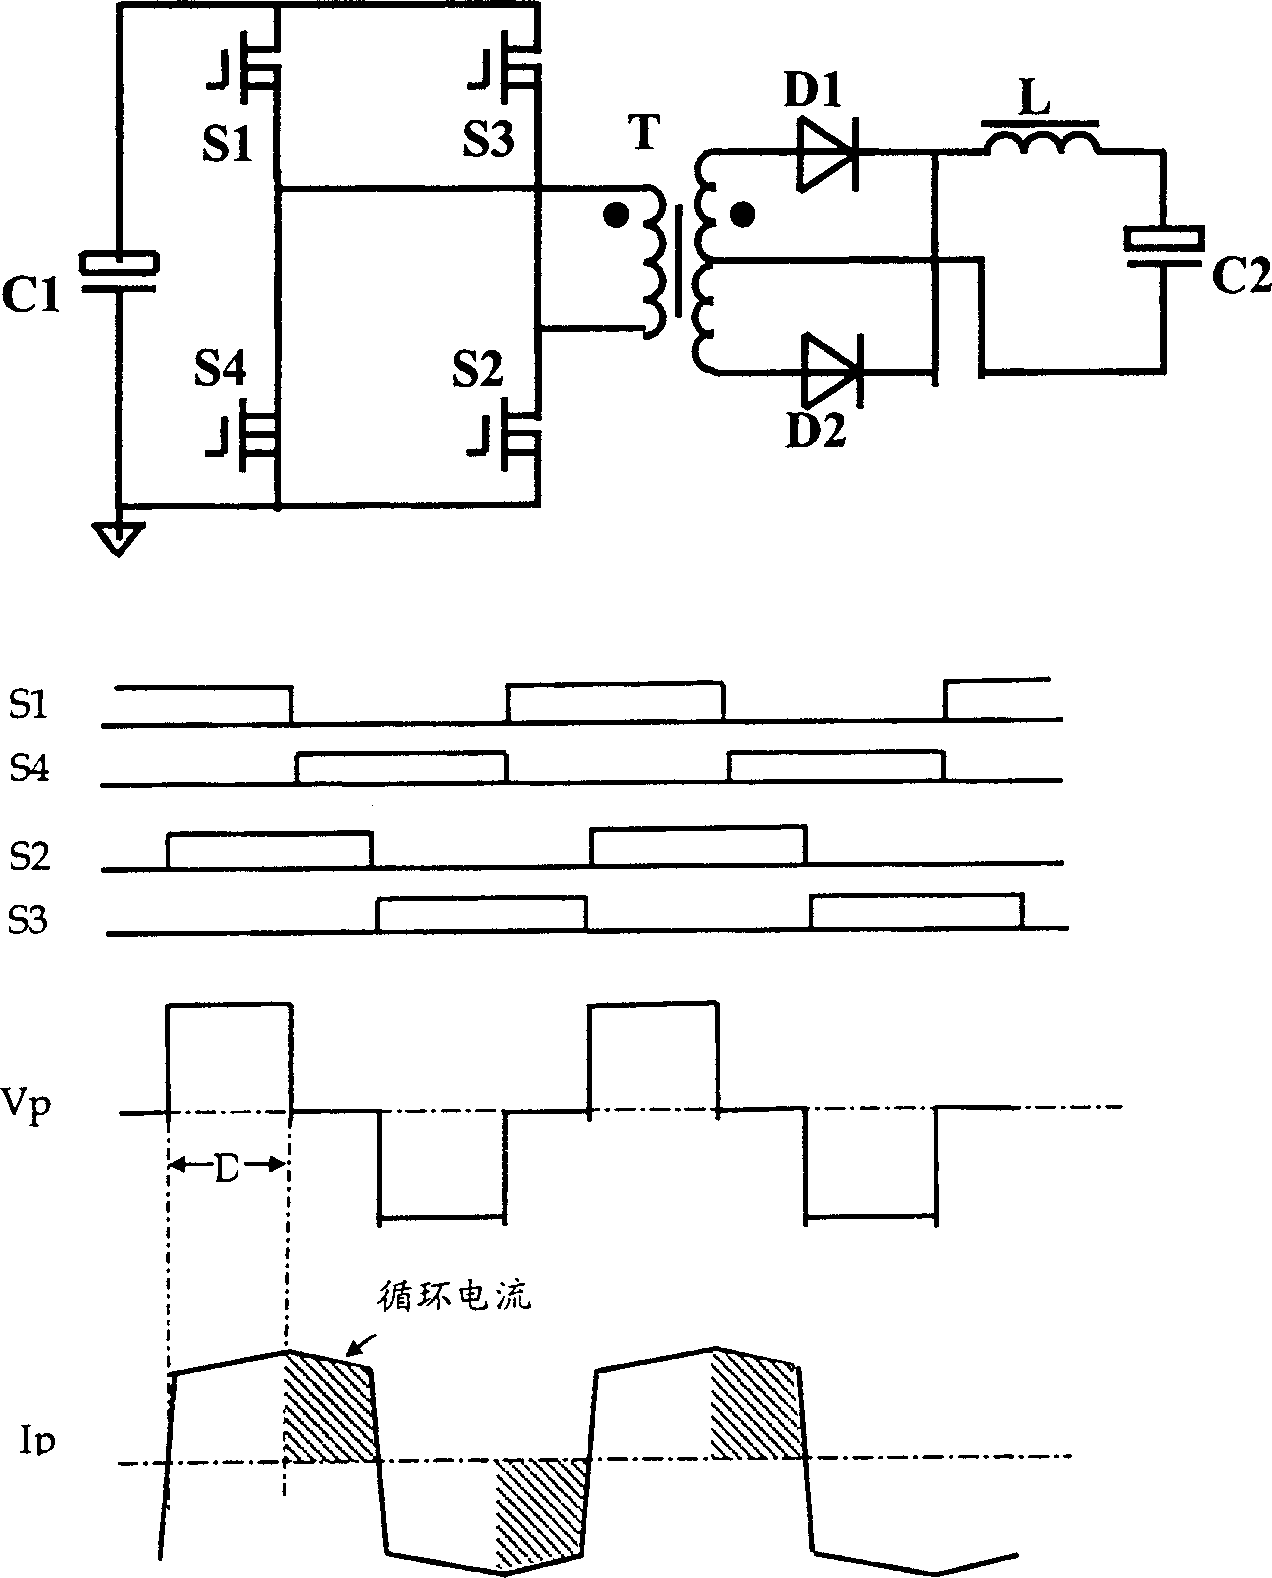
The present invention provides an asymmetric full-bridge DC / DC converter, which includes an asymmetric full-bridge circuit, the full-bridge circuit includes two main switches and two auxiliary switches, and a capacitor is connected in series with the branch circuits of these auxiliary switches , and a transformer having a primary winding and a secondary winding. The primary winding of the transformer is connected to the common point of each branch of the full bridge. A rectifier circuit is connected to the secondary winding of the transformer to obtain a DC voltage output. In operation, an asymmetric control method is applied to these main and auxiliary switches. The main switch and the auxiliary switch are turned on and off complementary. The linear control characteristic of the output voltage to the duty ratio of the switch and the optimal return of the transformer core are achieved by the present invention.
Owner:DELTA ELECTRONICS INC
Double-frequency microstrip cross branch-line coupler
InactiveCN105789808ASimple structureThe frequency is larger than the rangeCoupling devicesSpurlineImpedance Converter
The invention provides a double-frequency microstrip cross branch-line coupler comprising a base, and an input port, a direct-through output port, a coupling output port and an isolation port which are arranged on the base. The double-frequency microstrip cross branch-line coupler also comprises a first microstrip cross joint, a second microstrip cross joint, a third microstrip cross joint and a fourth microstrip cross joint. The first microstrip cross joint is connected between the input port and the direct-through output port. The second microstrip cross joint is connected between the direct-through output port and the coupling output port. The third microstrip cross joint is connected between the coupling output port and the isolation port. The fourth microstrip cross joint is connected between the isolation port and the input port. The conventional 1 / 4 wavelength impedance converter is replaced by a cross resonator model based on the conventional branch-line coupler structure, and the parameter values of corresponding elements are obtained through ABCD matrix analysis deduction and calculation so that port matching and port isolation can be realized, and the double-frequency microstrip cross branch-line coupler also has advantages of large frequency ratio range and small size.
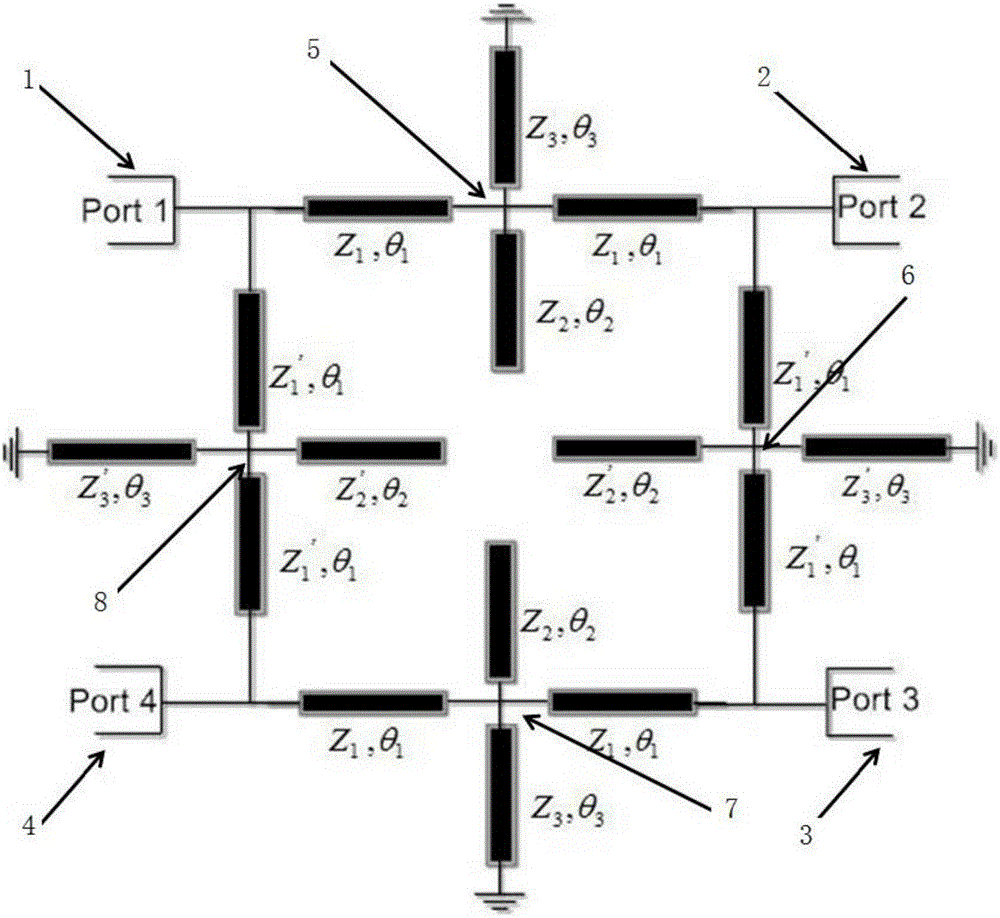
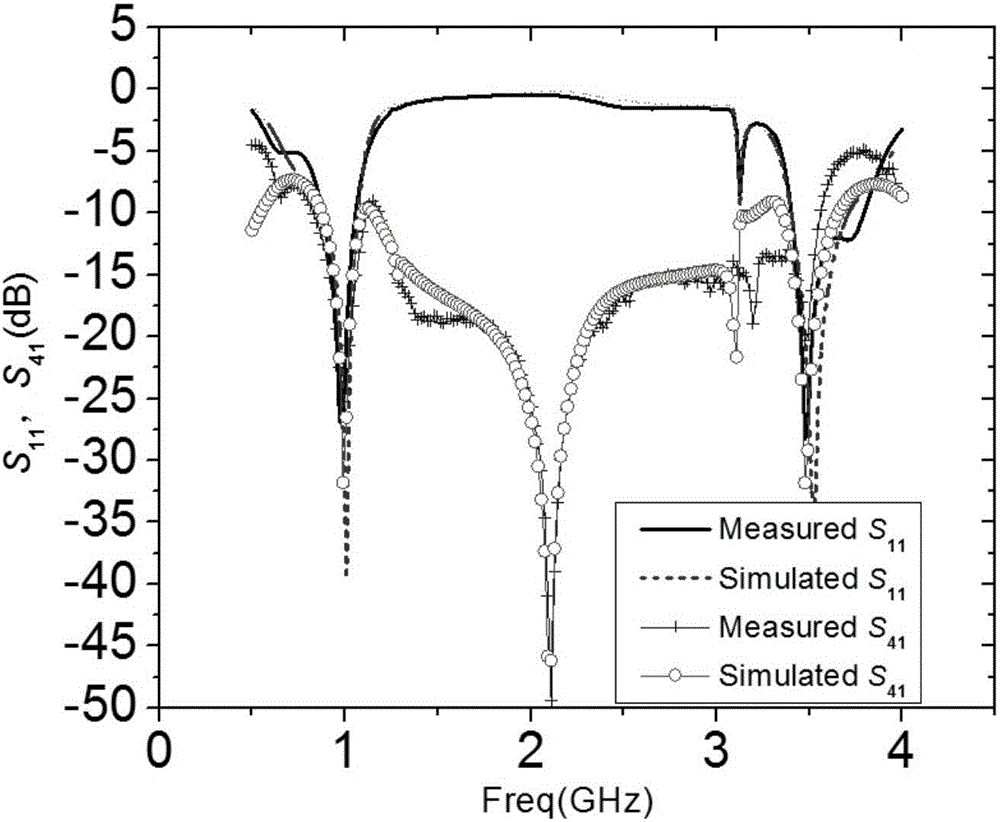
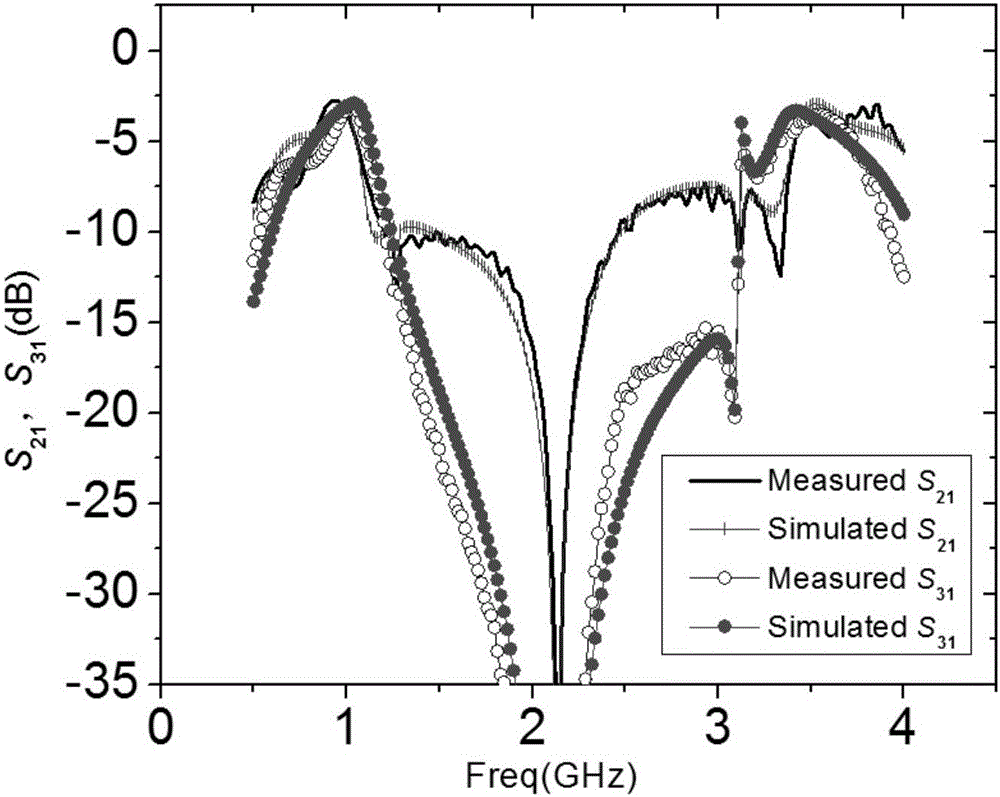
Owner:NANJING UNIV OF SCI & TECH
Ultra wideband dual-frequency pass-band filter based on stepped impedance resonator
The invention discloses an ultra wideband dual-frequency pass-band filter based on a stepped impedance resonator. The ultra wideband dual-frequency pass-band filter comprises a first input-output end (101), a second input-output end (102), a first open-loop stepped impedance resonator (103), a second open-loop stepped impedance resonator (104), a first loading double-branch line (105), a second loading double-branch line (106), a dielectric substrate (107) and a metal grounding plate (108) under the dielectric substrate. The filter has the advantages of simple design, compact structure and low cost, and is convenient to process, and adjustable dual-frequency pass-band performance can be achieved.
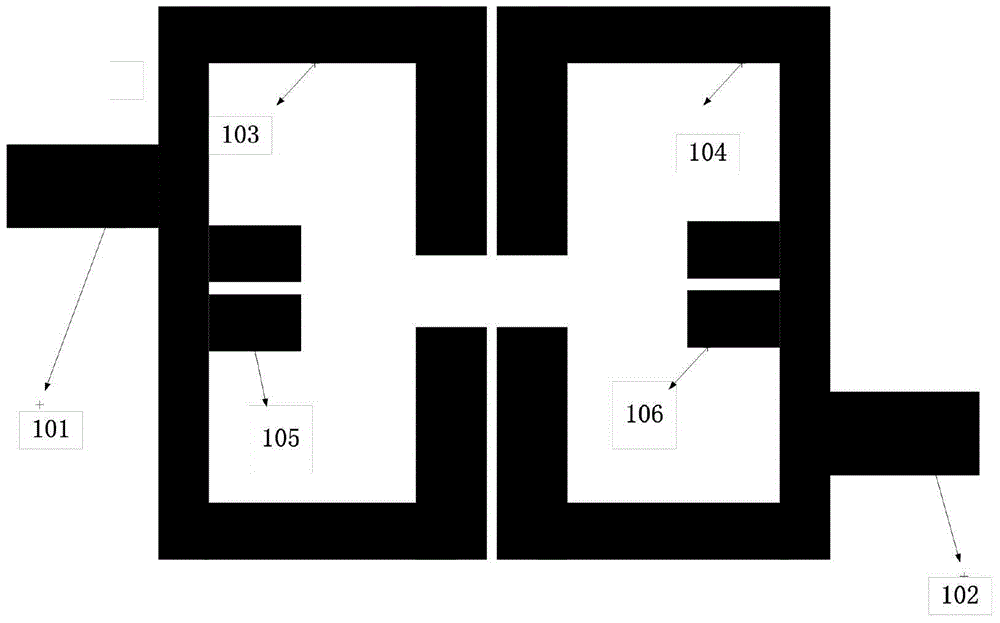
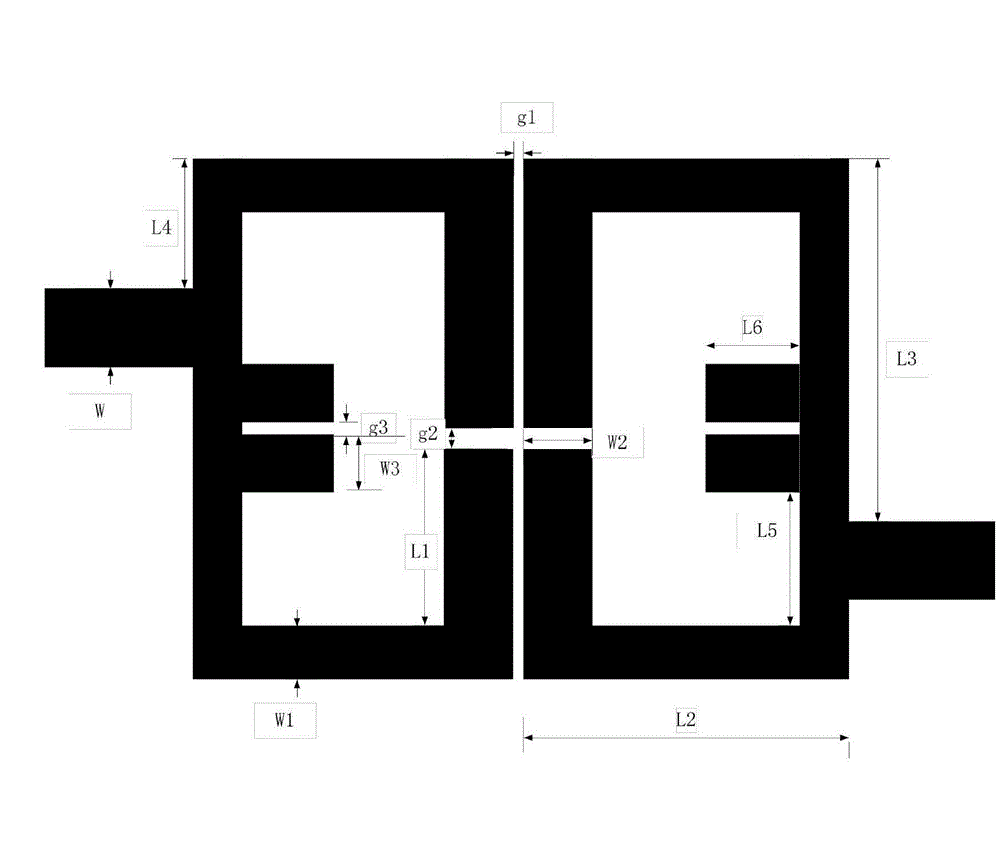
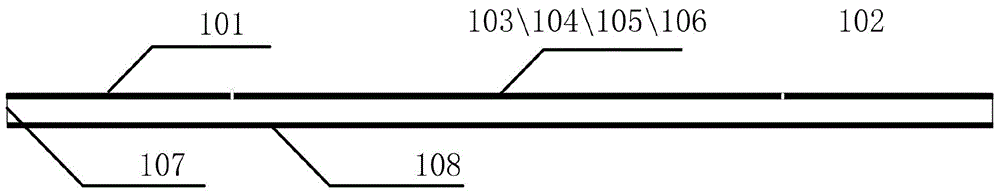
Owner:HARBIN HESON SCI & TECH
A Broadband Printed Dipole Antenna with Novel Branch Line Integrated Feed Balun
ActiveCN103531895BHigh bandwidthDoes not affect other performanceRadiating elements structural formsResonant antenna detailsSpurlineAntenna bandwidth
The invention discloses a novel broadband printed dipole antenna with a branch wire integrated with a feed balun. The novel broadband printed dipole antenna comprises an SMA (Shape Memory Alloy) joint, a dielectric-slab, a radiating element and a microstrip line feed integrated balun, wherein the radiating element is provided with a slotting seam; dual radiation arms are formed on both sides of the slotting seam; the microstrip line feed integrated balun is provided with a branch wire; the branch wire is equivalent to a series resistor, and is used for improving the matched impedance. According to the novel broadband printed dipole antenna, the VSWR (Voltage Standing Wave Ratio) is less than or equal to 1.5, and the relative bandwidth is up to 58.7 percent (1.65-3.0GHz); compared with other bandwidth extension technologies (such as a parasitic patch increasing technology), the novel broadband printed dipole antenna has the advantages that design is made on the basis of not changing the original size of the antenna, so that the bandwidth of the antenna is improved, other performance of the antenna (such as gain and cross polarization level) is not influenced, and the occupied space is reduced; the novel broadband printed dipole antenna has the advantages of simple structure, convenience, practicability, wide adaptability and the like.
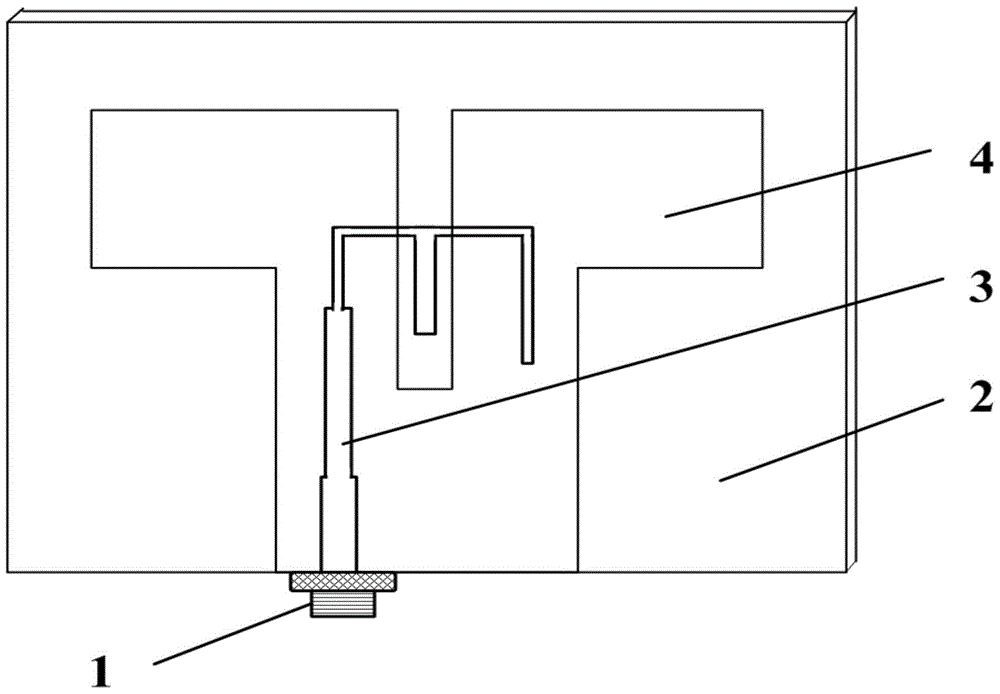
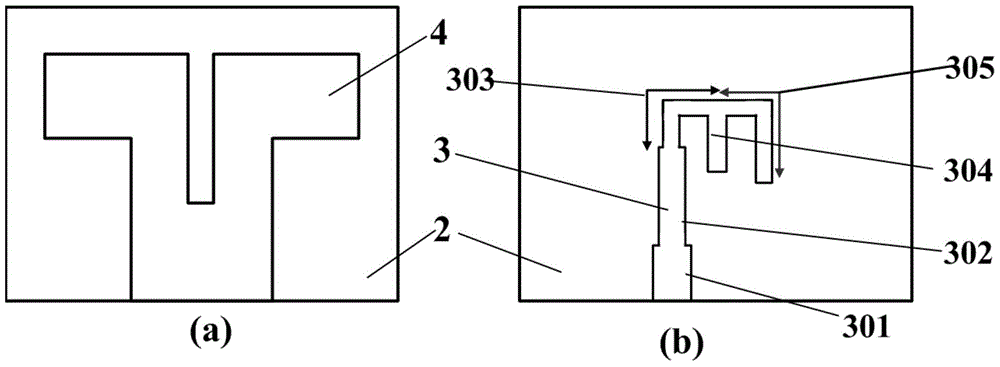
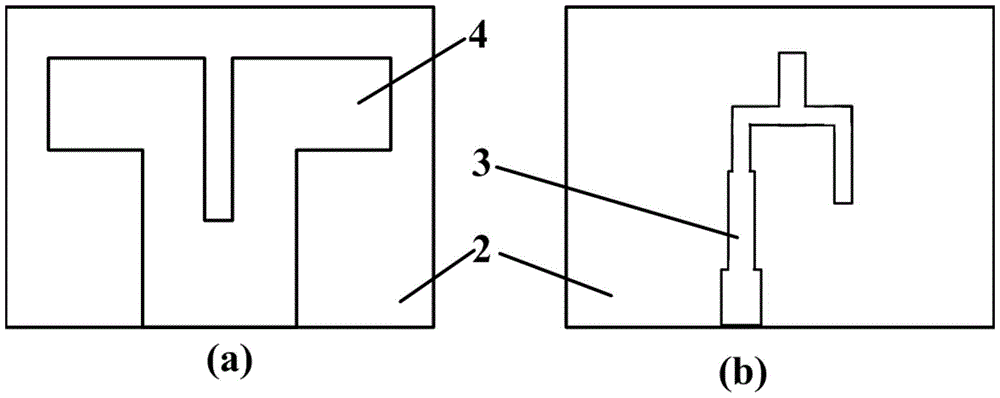
Owner:HUAQIAO UNIVERSITY
MMIC InGaP HBT power amplifier
InactiveCN101667811AGood harmonic suppression effectGood linearityPower amplifiersAmplifier modifications to raise efficiencyHbt power amplifierMicrowave
The invention relates to an MMIC InGaP HBT power amplifier, and an asymmetric spurline structure consisting of a first spurline (4) and a second spurline (5) with the different lengths is loaded on anoutput port (3) of the MMIC InGaP HBT power amplifier. The regulation of the length difference (6) of the asymmetric spurline structure can lead the output port (3) of the MMIC InGaP HBT power amplifier to have the filter feature of two stop-bands, lead the MMIC InGaP HBT power amplifier to have excellent harmonic suppression ability, greatly upgrade the linear feature of output signals, producethe stop-band feature at the second harmonic and the third harmonic and greatly reduce harmonic components. The invention has the advantages of compact design, easy integration and convenient use in adense integrated circuit, thereby being applicable to suppress high-order harmonics for microwave circuits.
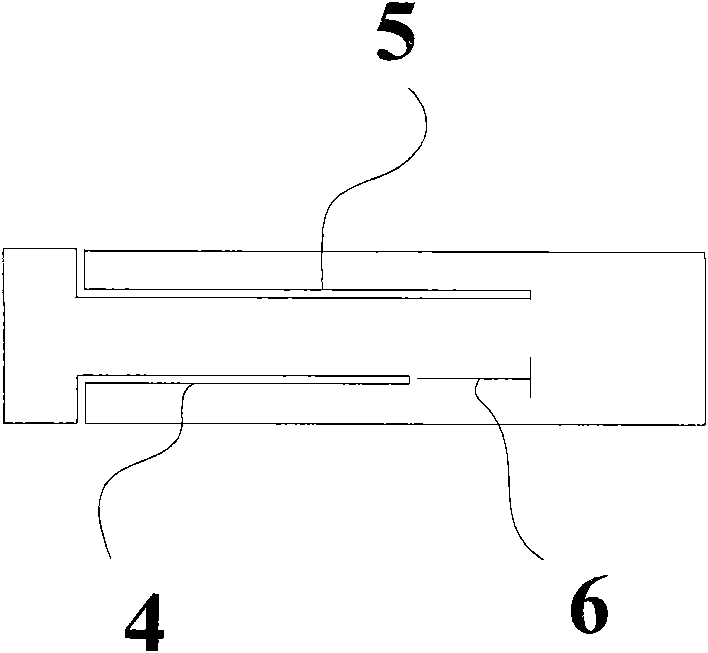
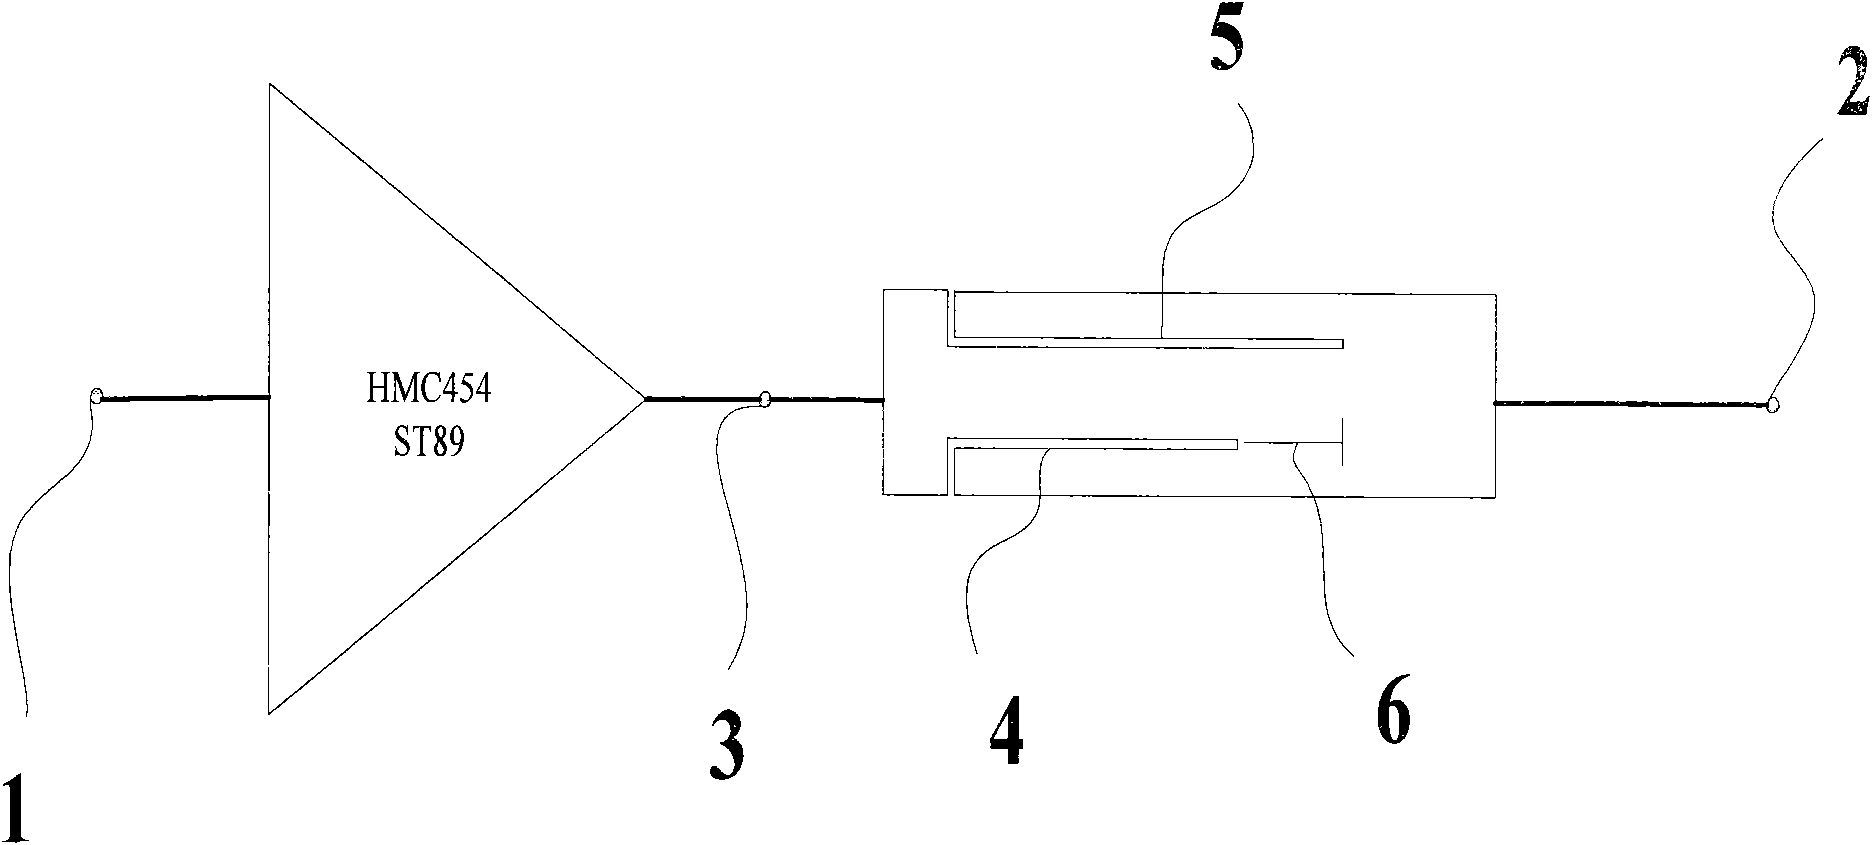
Owner:EAST CHINA JIAOTONG UNIVERSITY
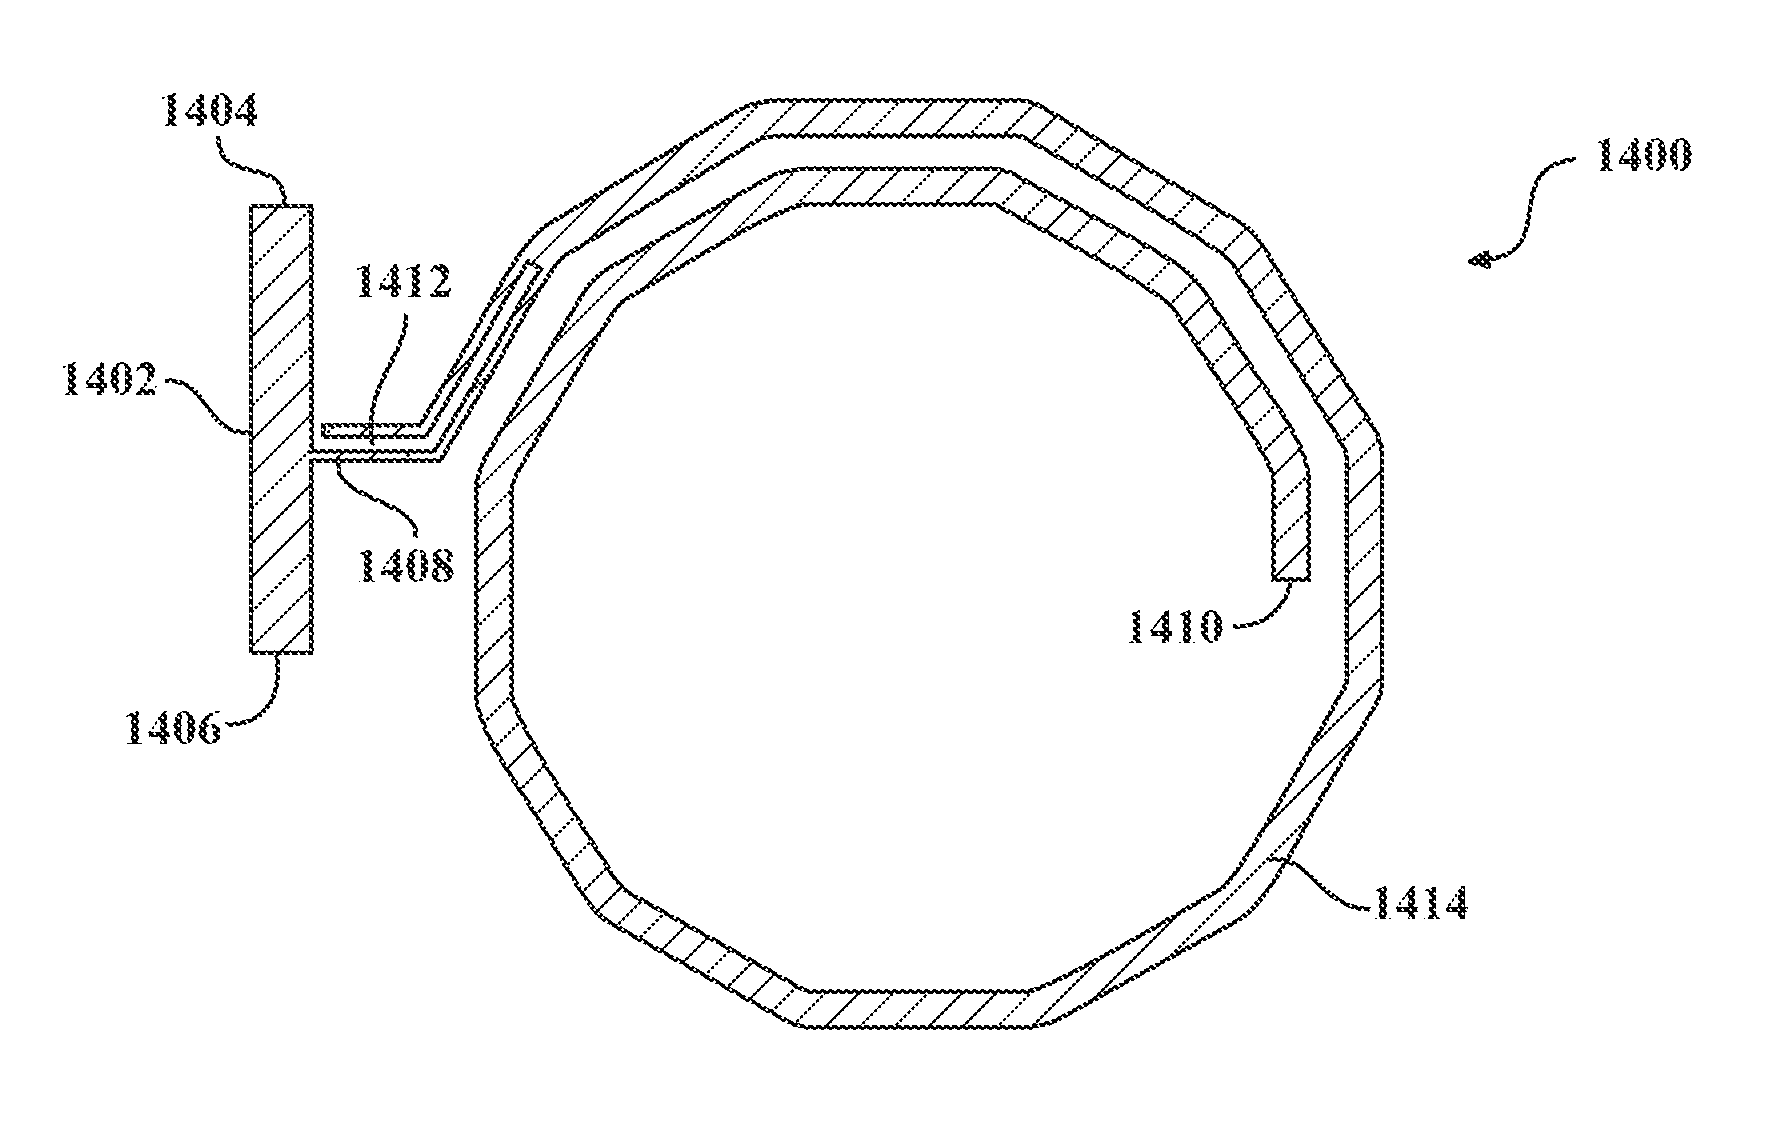
Capacitively loaded spurline filter
In an exemplary embodiment, a spurline filter comprises a capacitive element connected to a spur and either a through-line of the spurline filter or ground. In another embodiment, multiple capacitive elements are connected to the spur. In an exemplary embodiment, the capacitively loaded spurline filter provides a band rejection frequency response similar to the band rejection frequency response of a similar spurline filter that does not comprise at least one capacitive element but the capacitively loaded spurline filter has half the layout area or less. In an exemplary embodiment, the spurline filter comprises capacitive elements, where the capacitive elements are configured to reduce the resonant frequency of the filter.
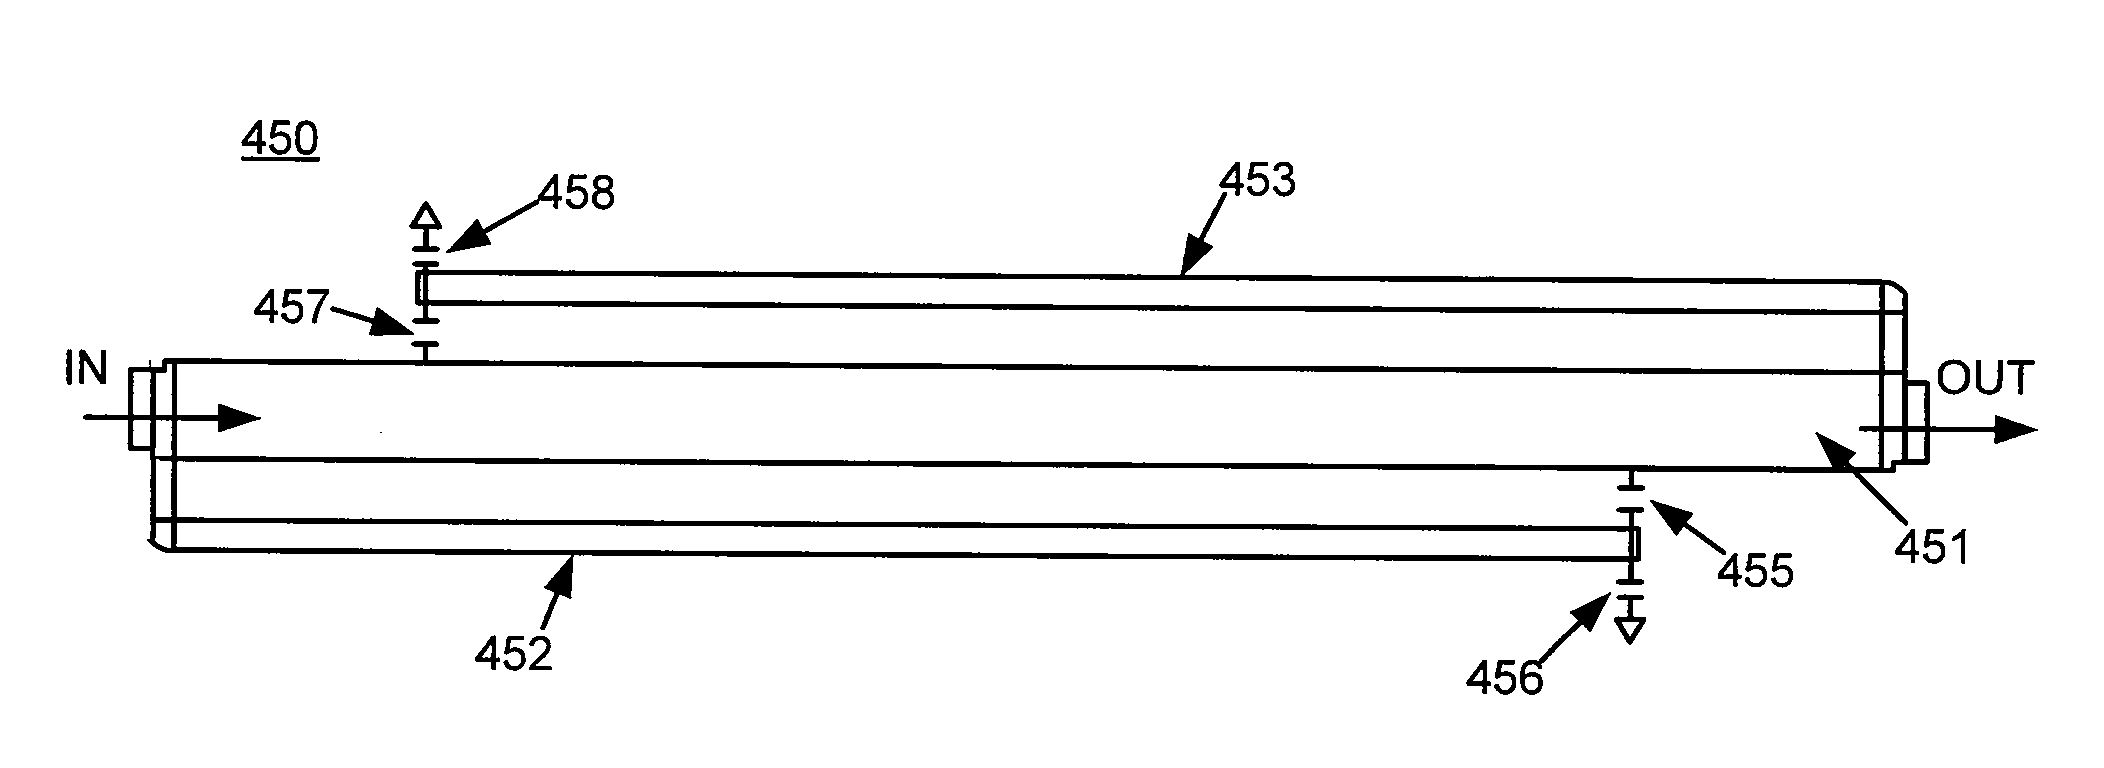
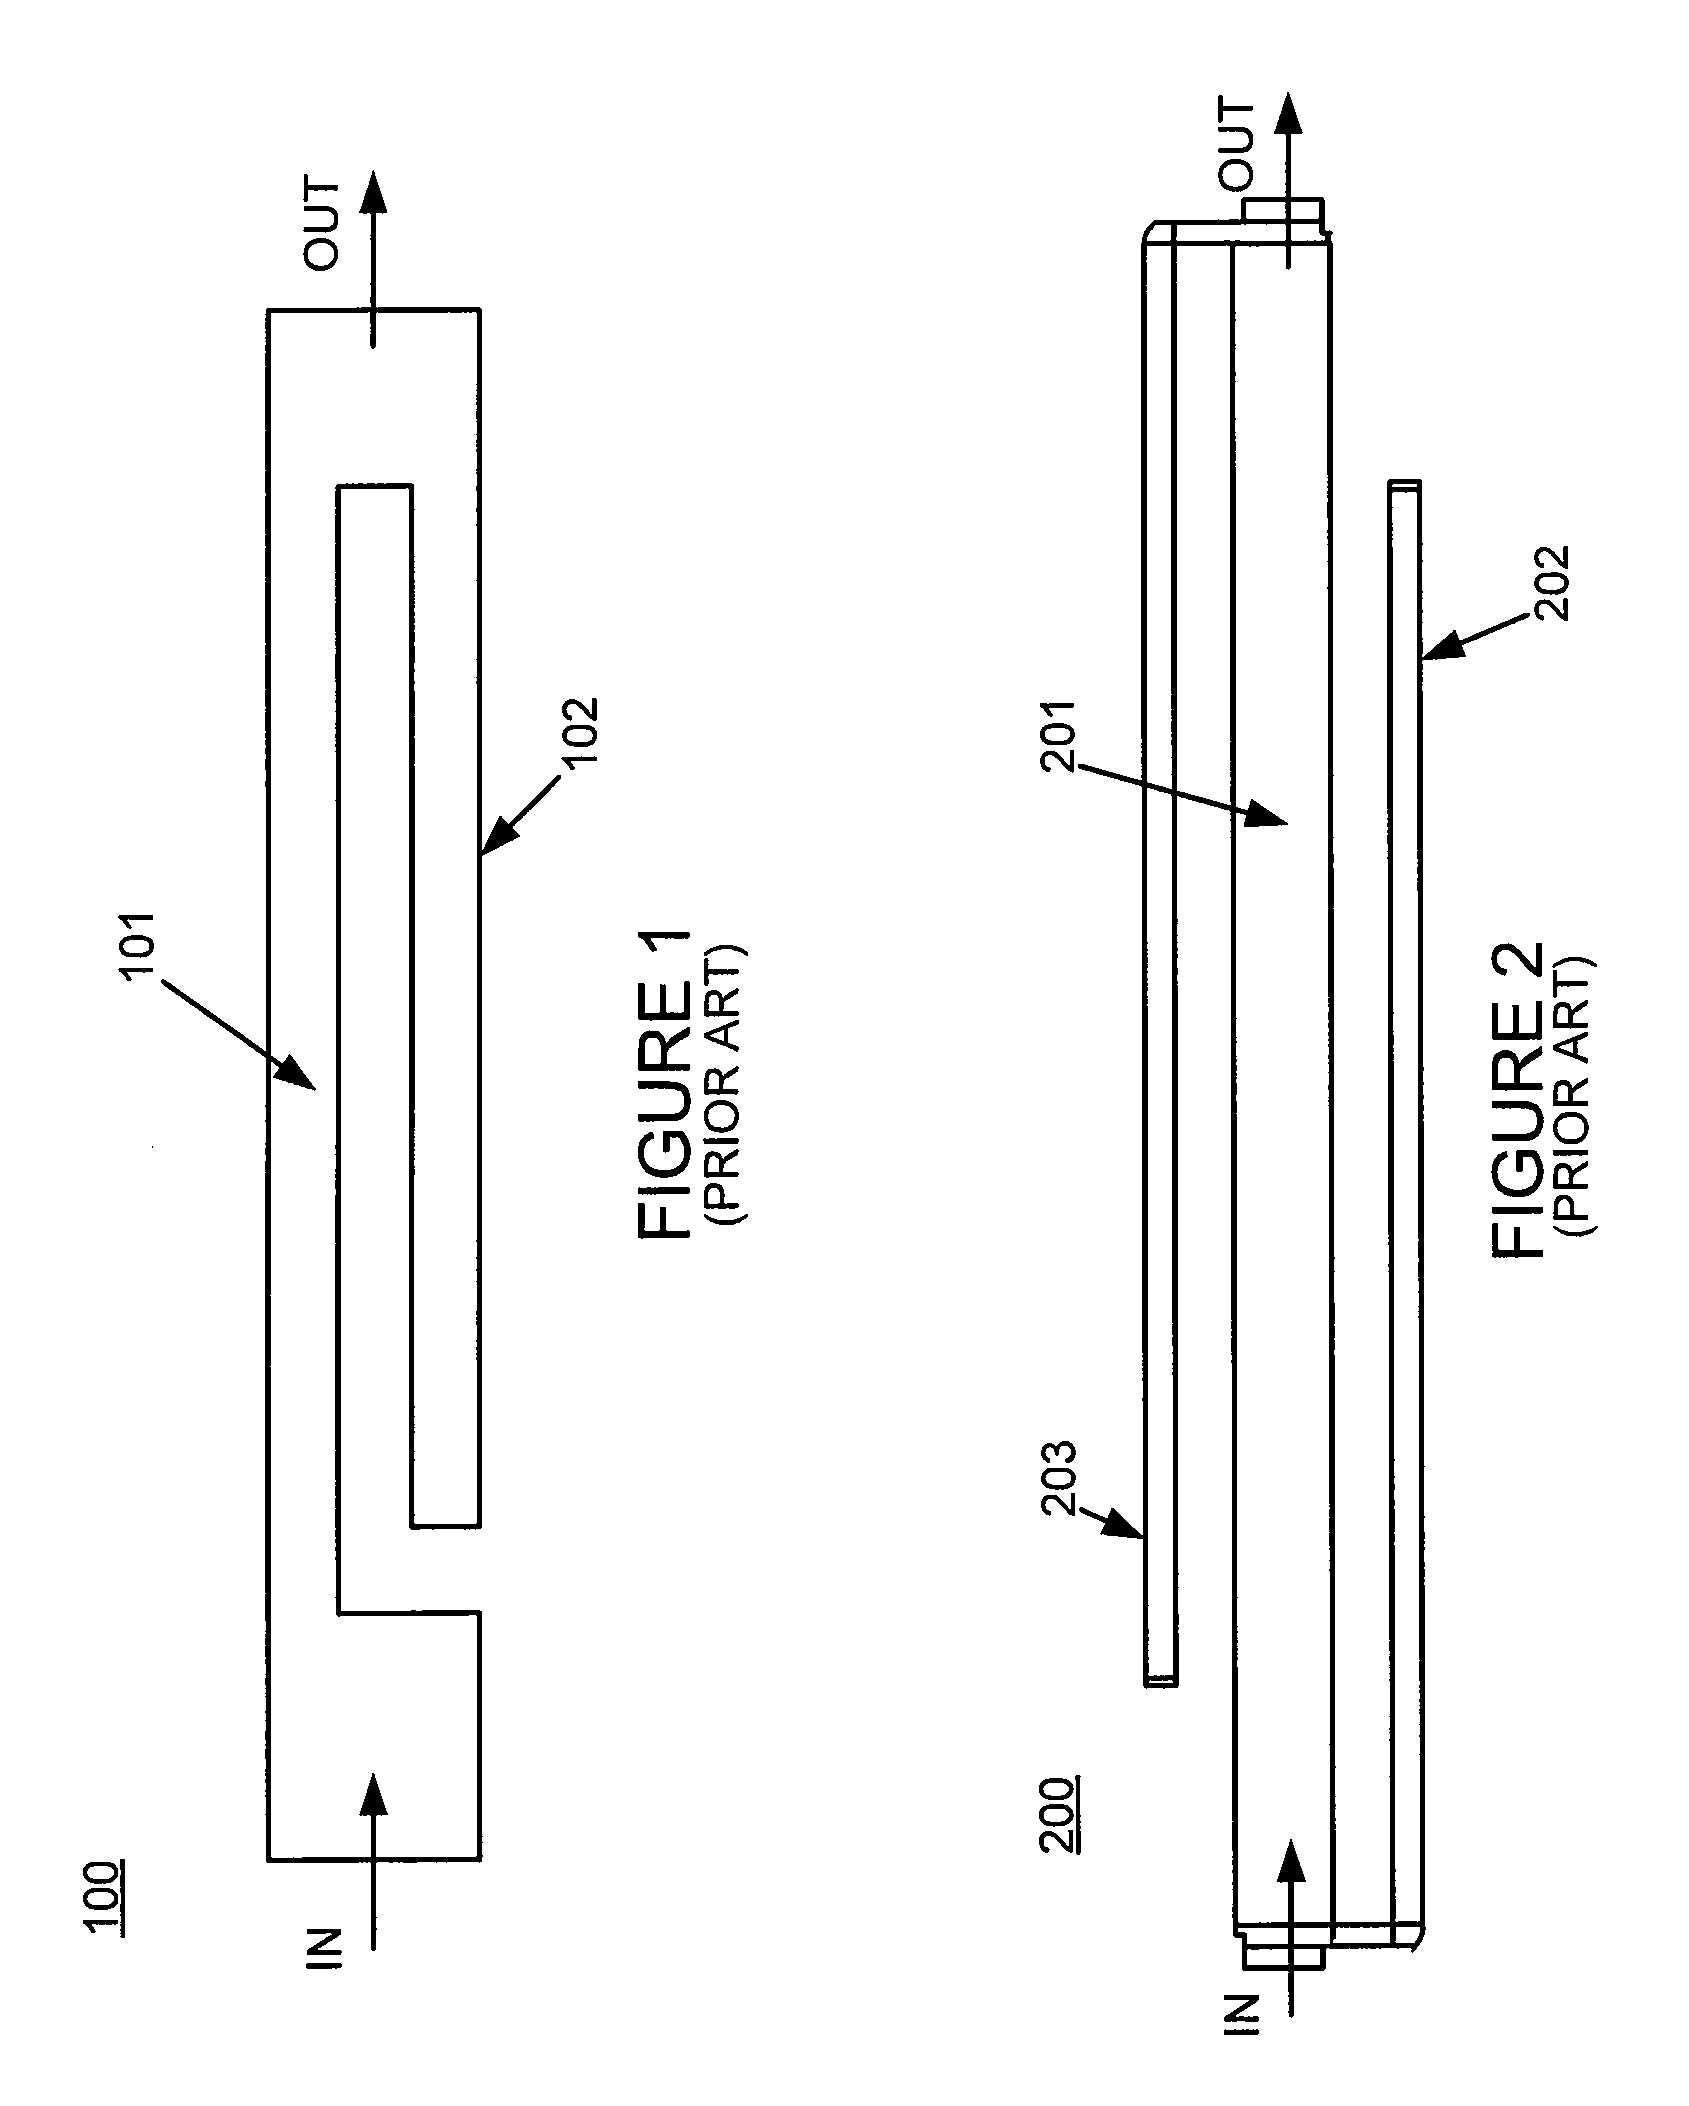
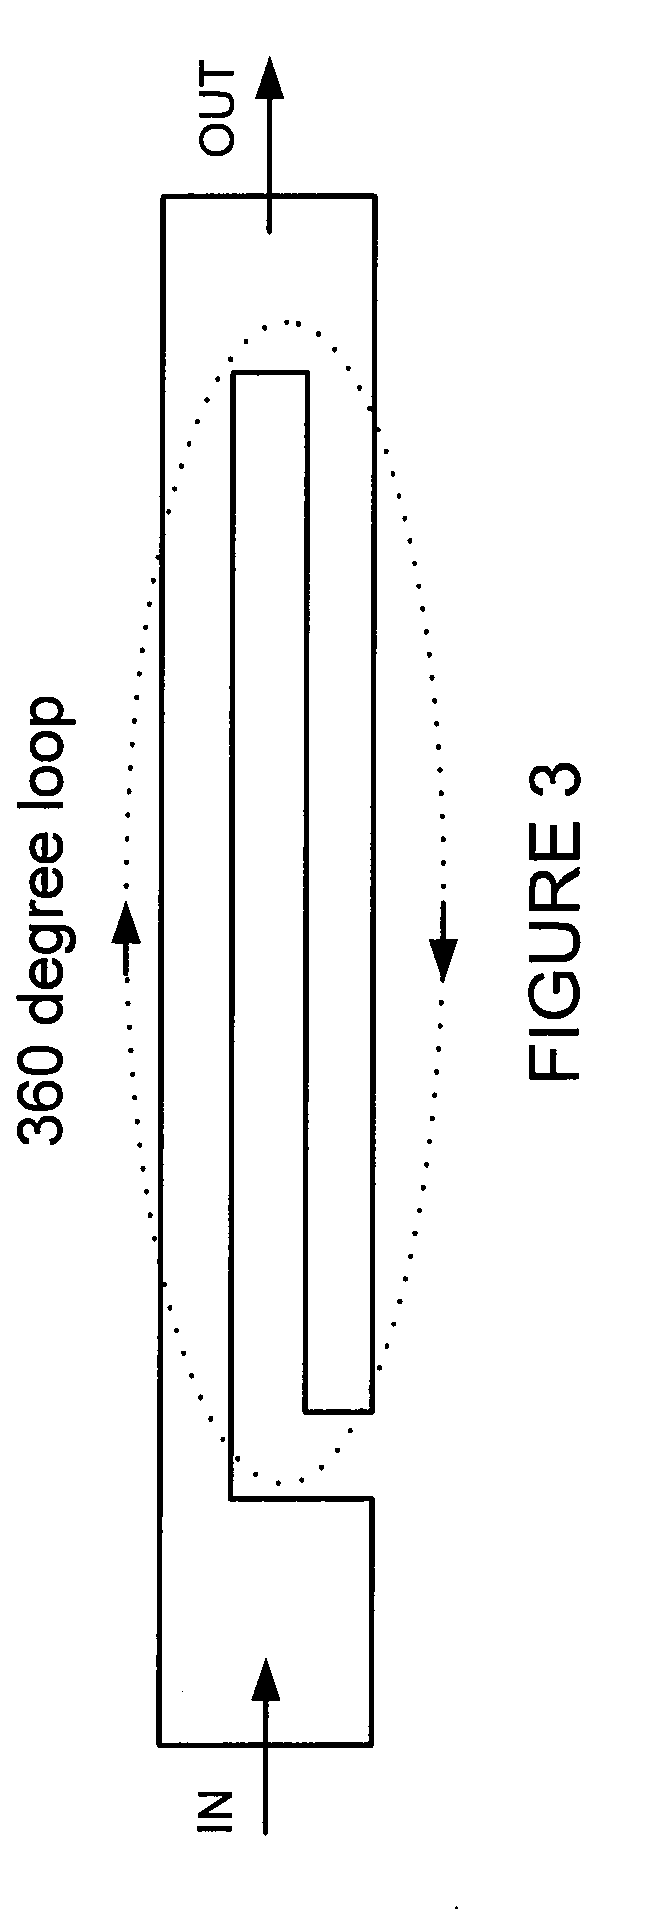
Owner:VIASAT INC
Arbitrary dual-frequency power divider based on right-left transmission line and its production method
The invention discloses an arbitrary dual-frequency Wilkinson power divider based on a composite left-handed transmission line, which includes three ports, four right-handed transmission lines, two left-handed transmission lines and isolation resistors; the method includes obtaining the frequency ratio of working frequency points, establishing the phase shift value of the transmission line, Create a port transmission line, create a right-hand transmission line, create a left-hand transmission line, and create an isolation circuit. The ordinary arbitrary dual-frequency Wilkinson power splitter produced by the present invention, the compact arbitrary dual-frequency power splitter based on the composite left-handed transmission line and negative phase shift technology, and the compact arbitrary dual-frequency power splitter of the double-section impedance transformation technology can overcome the traditional power splitter which can only be odd The defect of sub-frequency multiplication work is that the length of the branch line can be shortened to less than λg / 4, which satisfies dual-frequency work and has a compact structure. The power divider of the invention is simple in design, and the required microwave plates and components are easy to obtain and easy to process. The power splitter proposed by the invention can well meet the performance requirements of the power splitter at two operating frequency points.
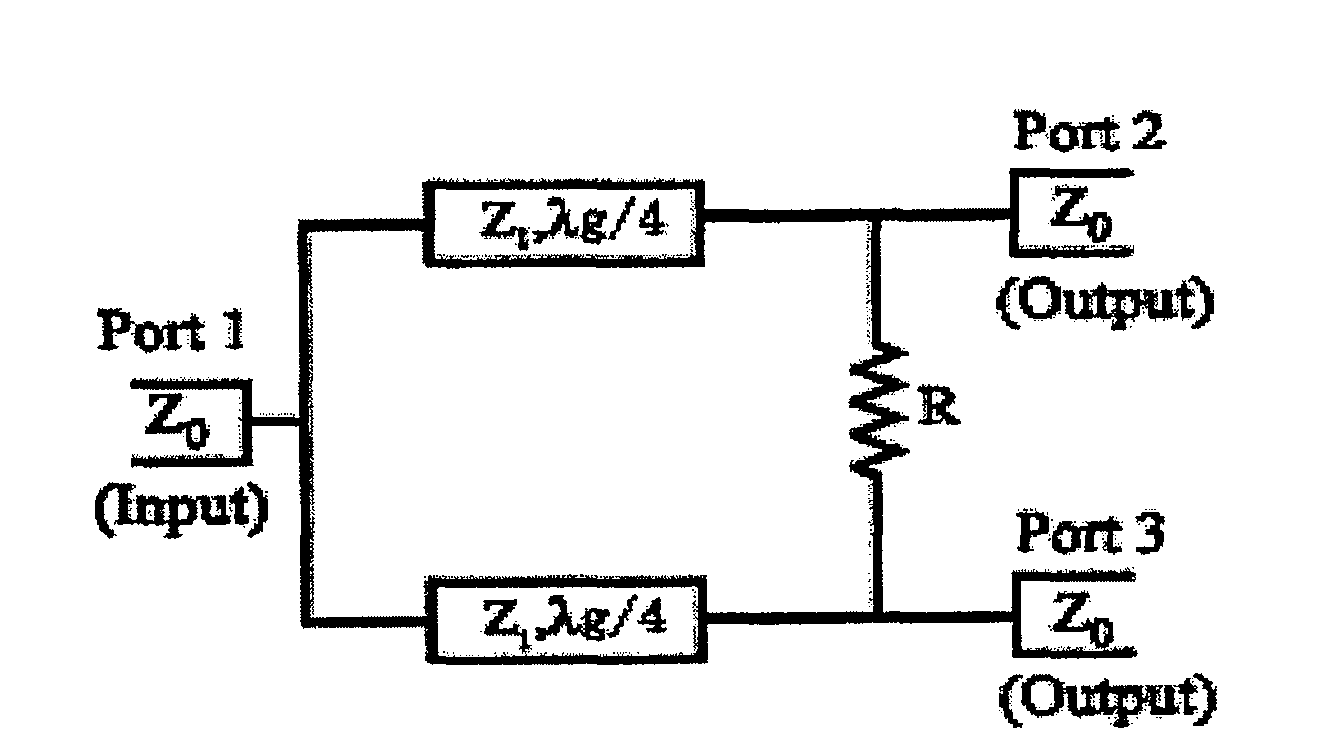
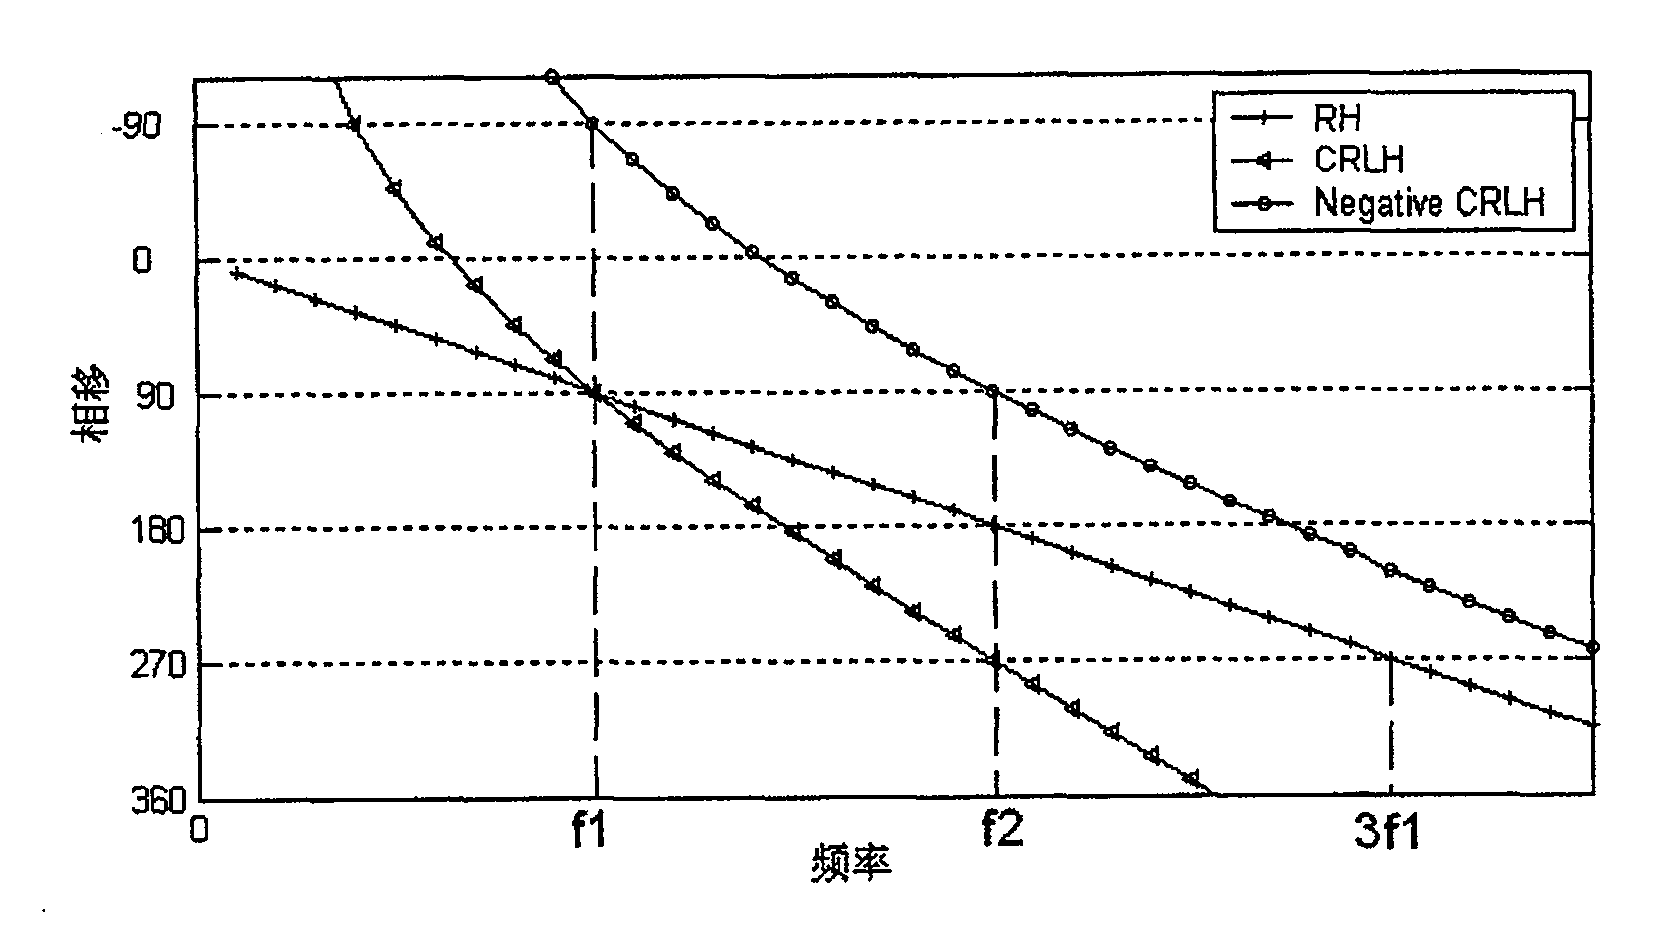
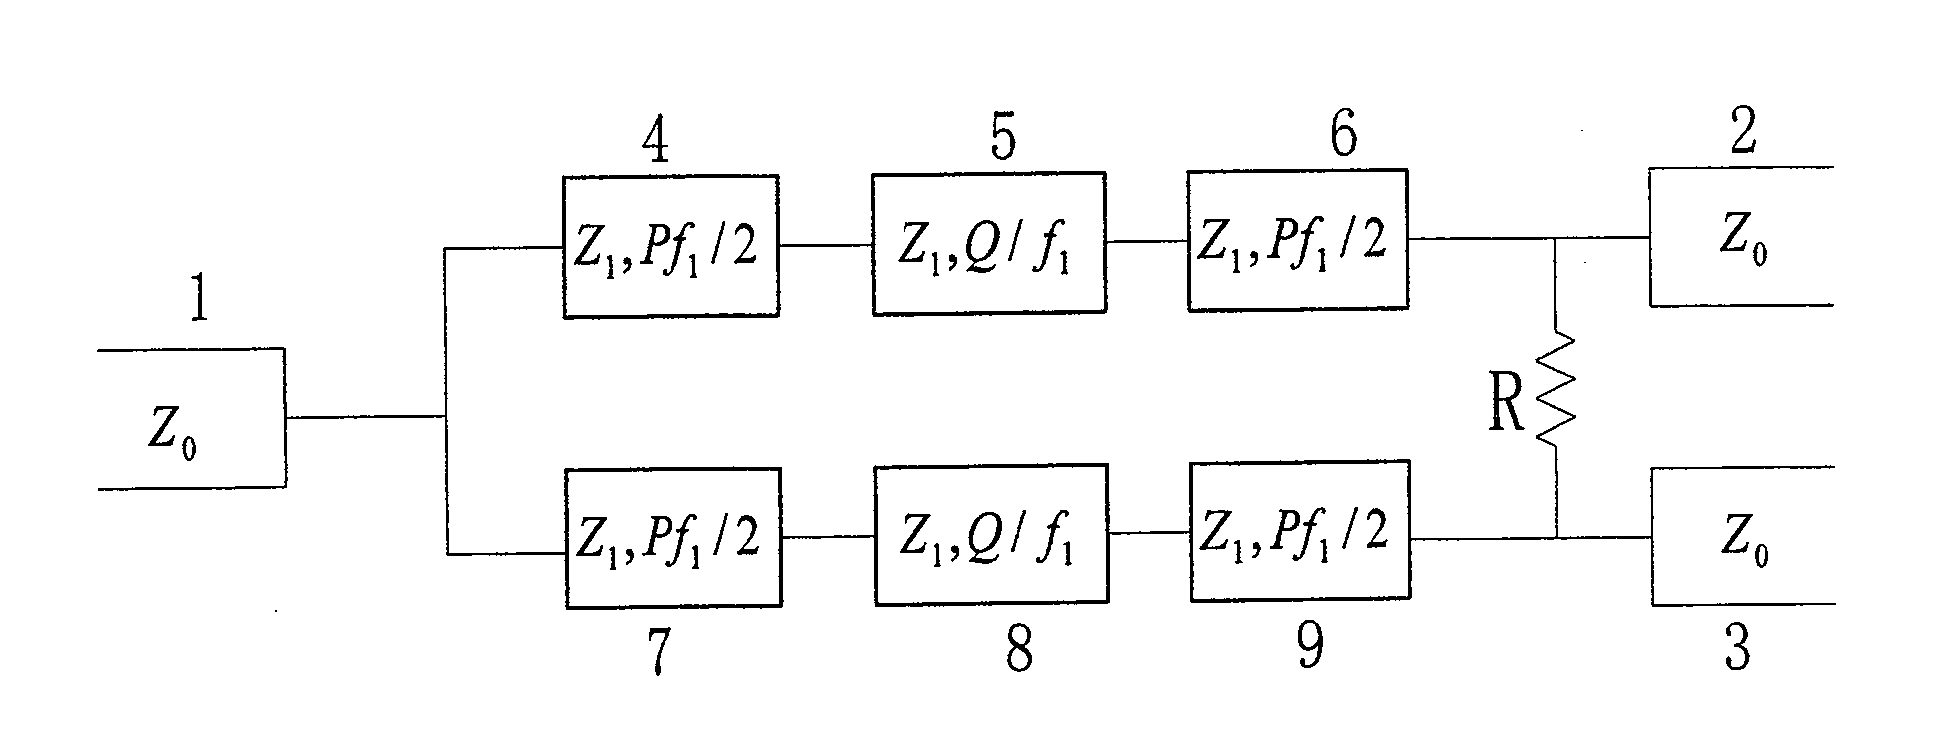
Owner:INST OF ELECTRONICS CHINESE ACAD OF SCI
Microwave filter
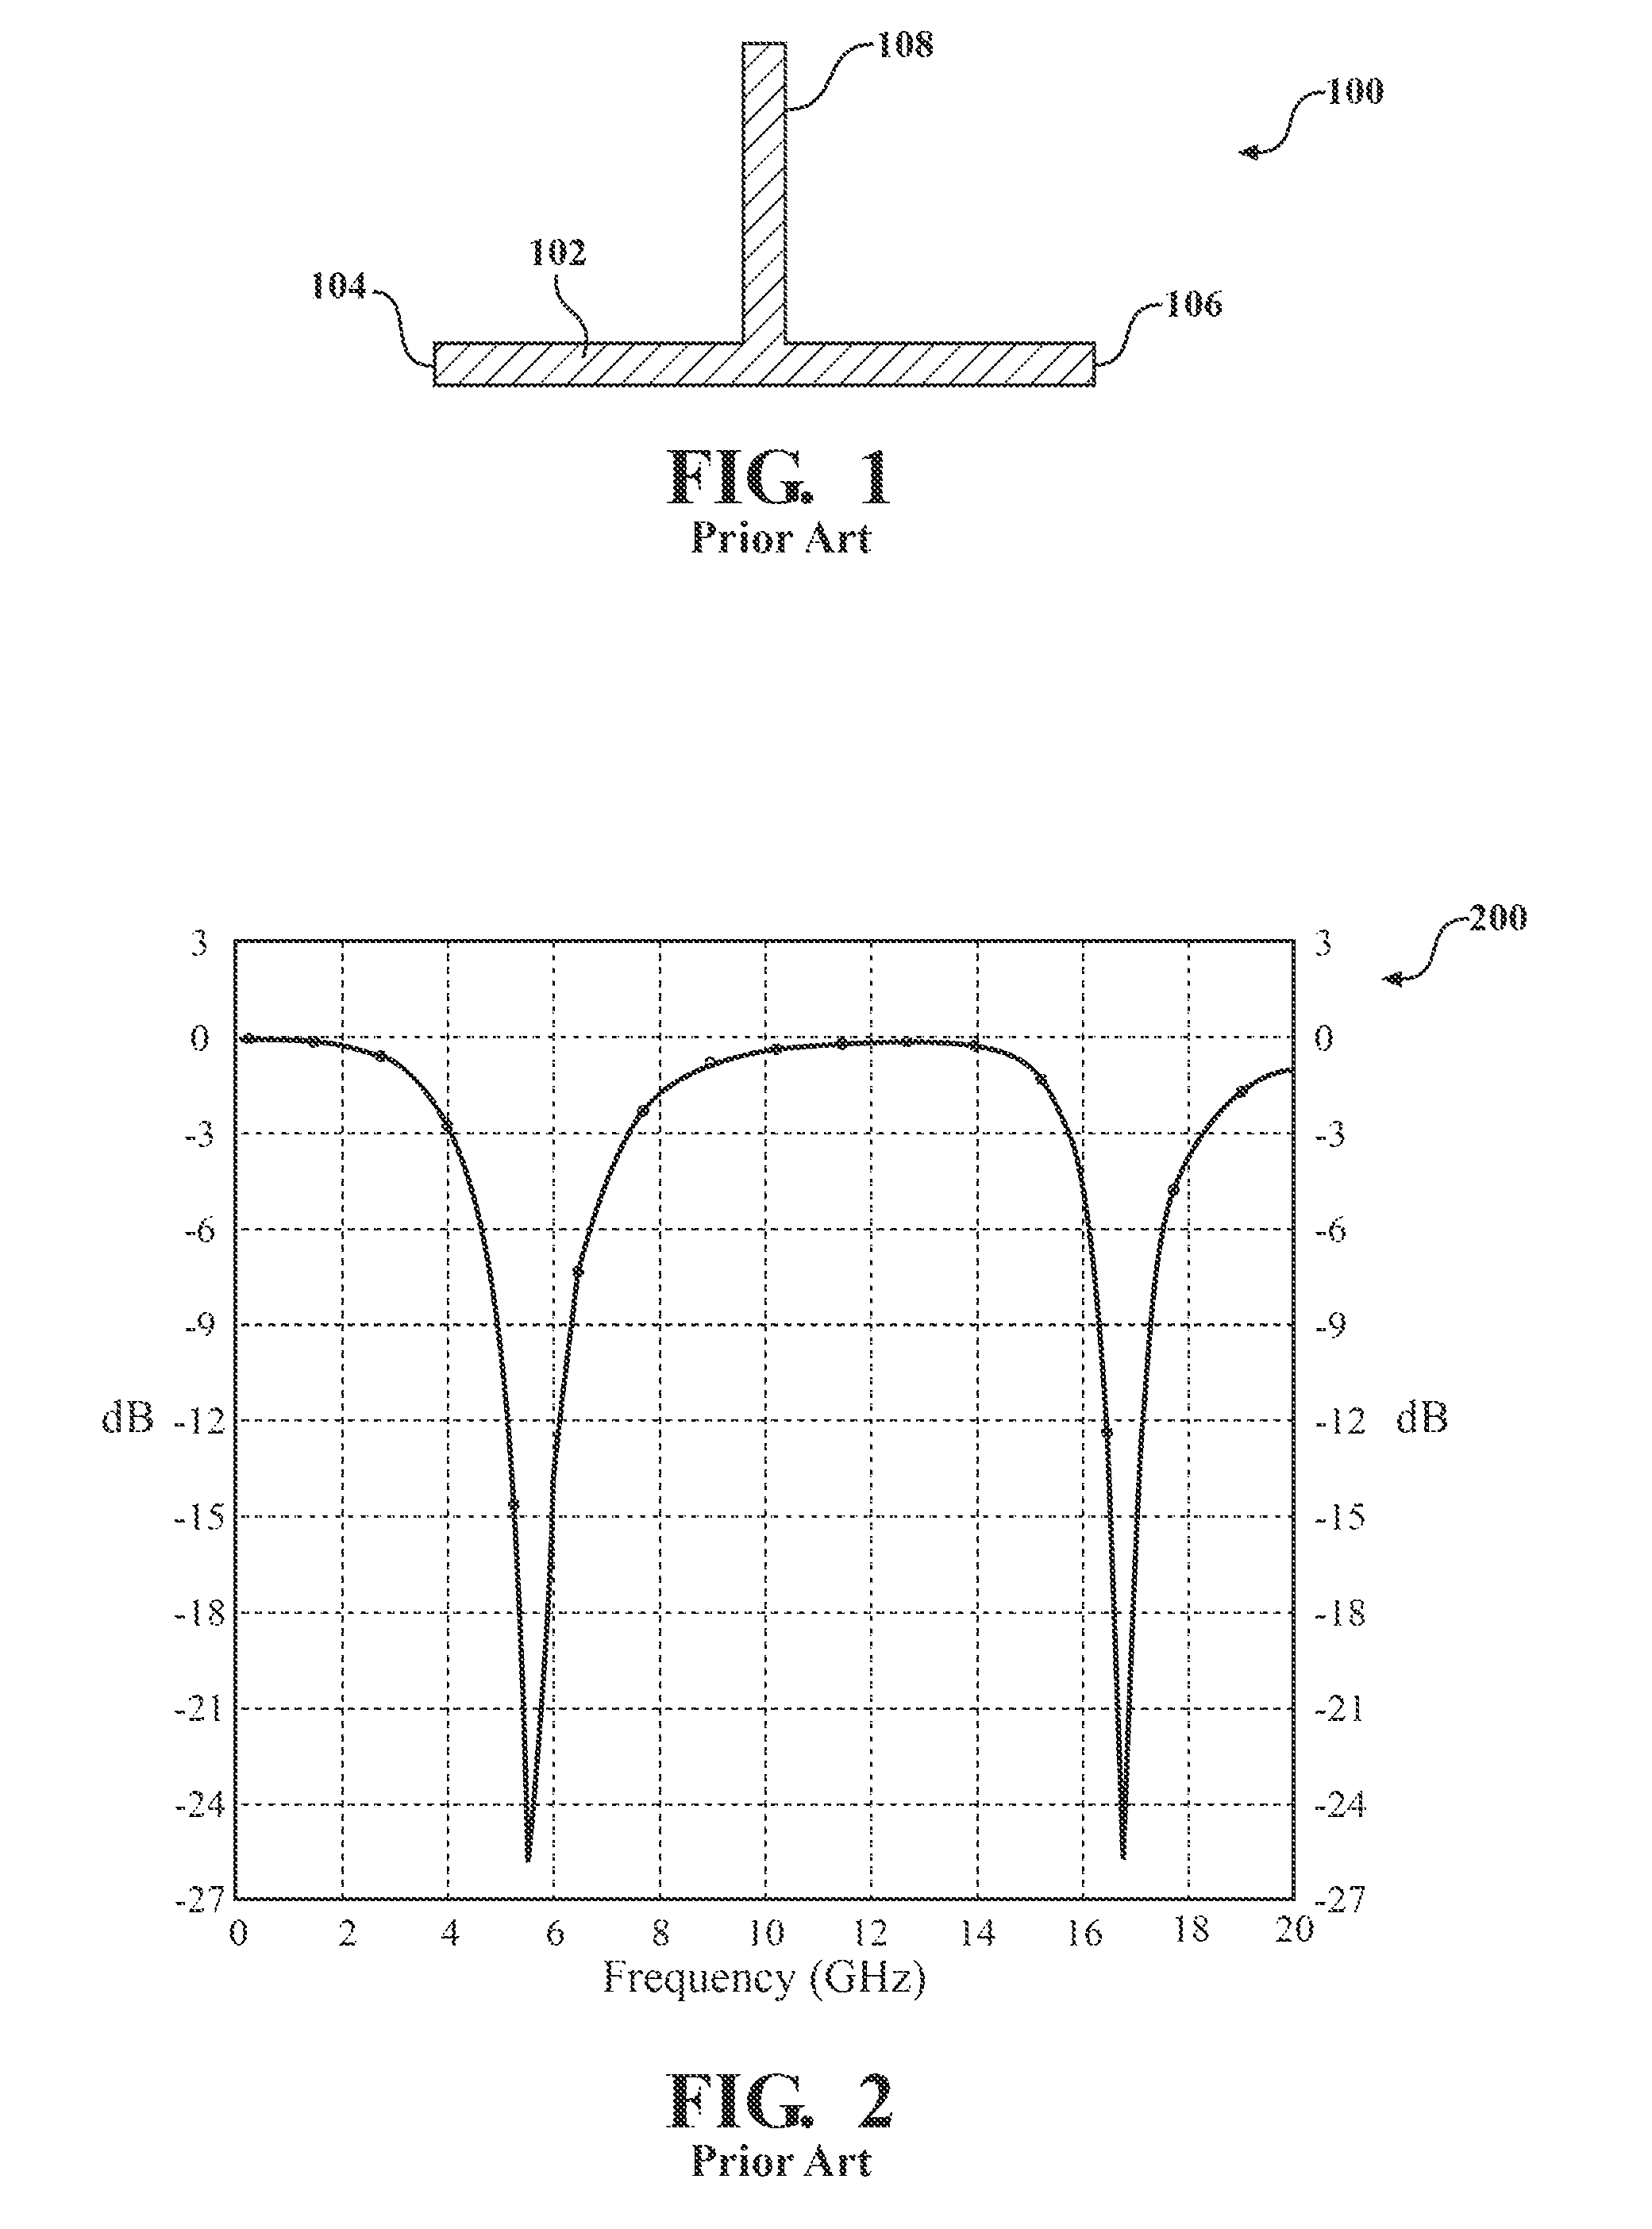
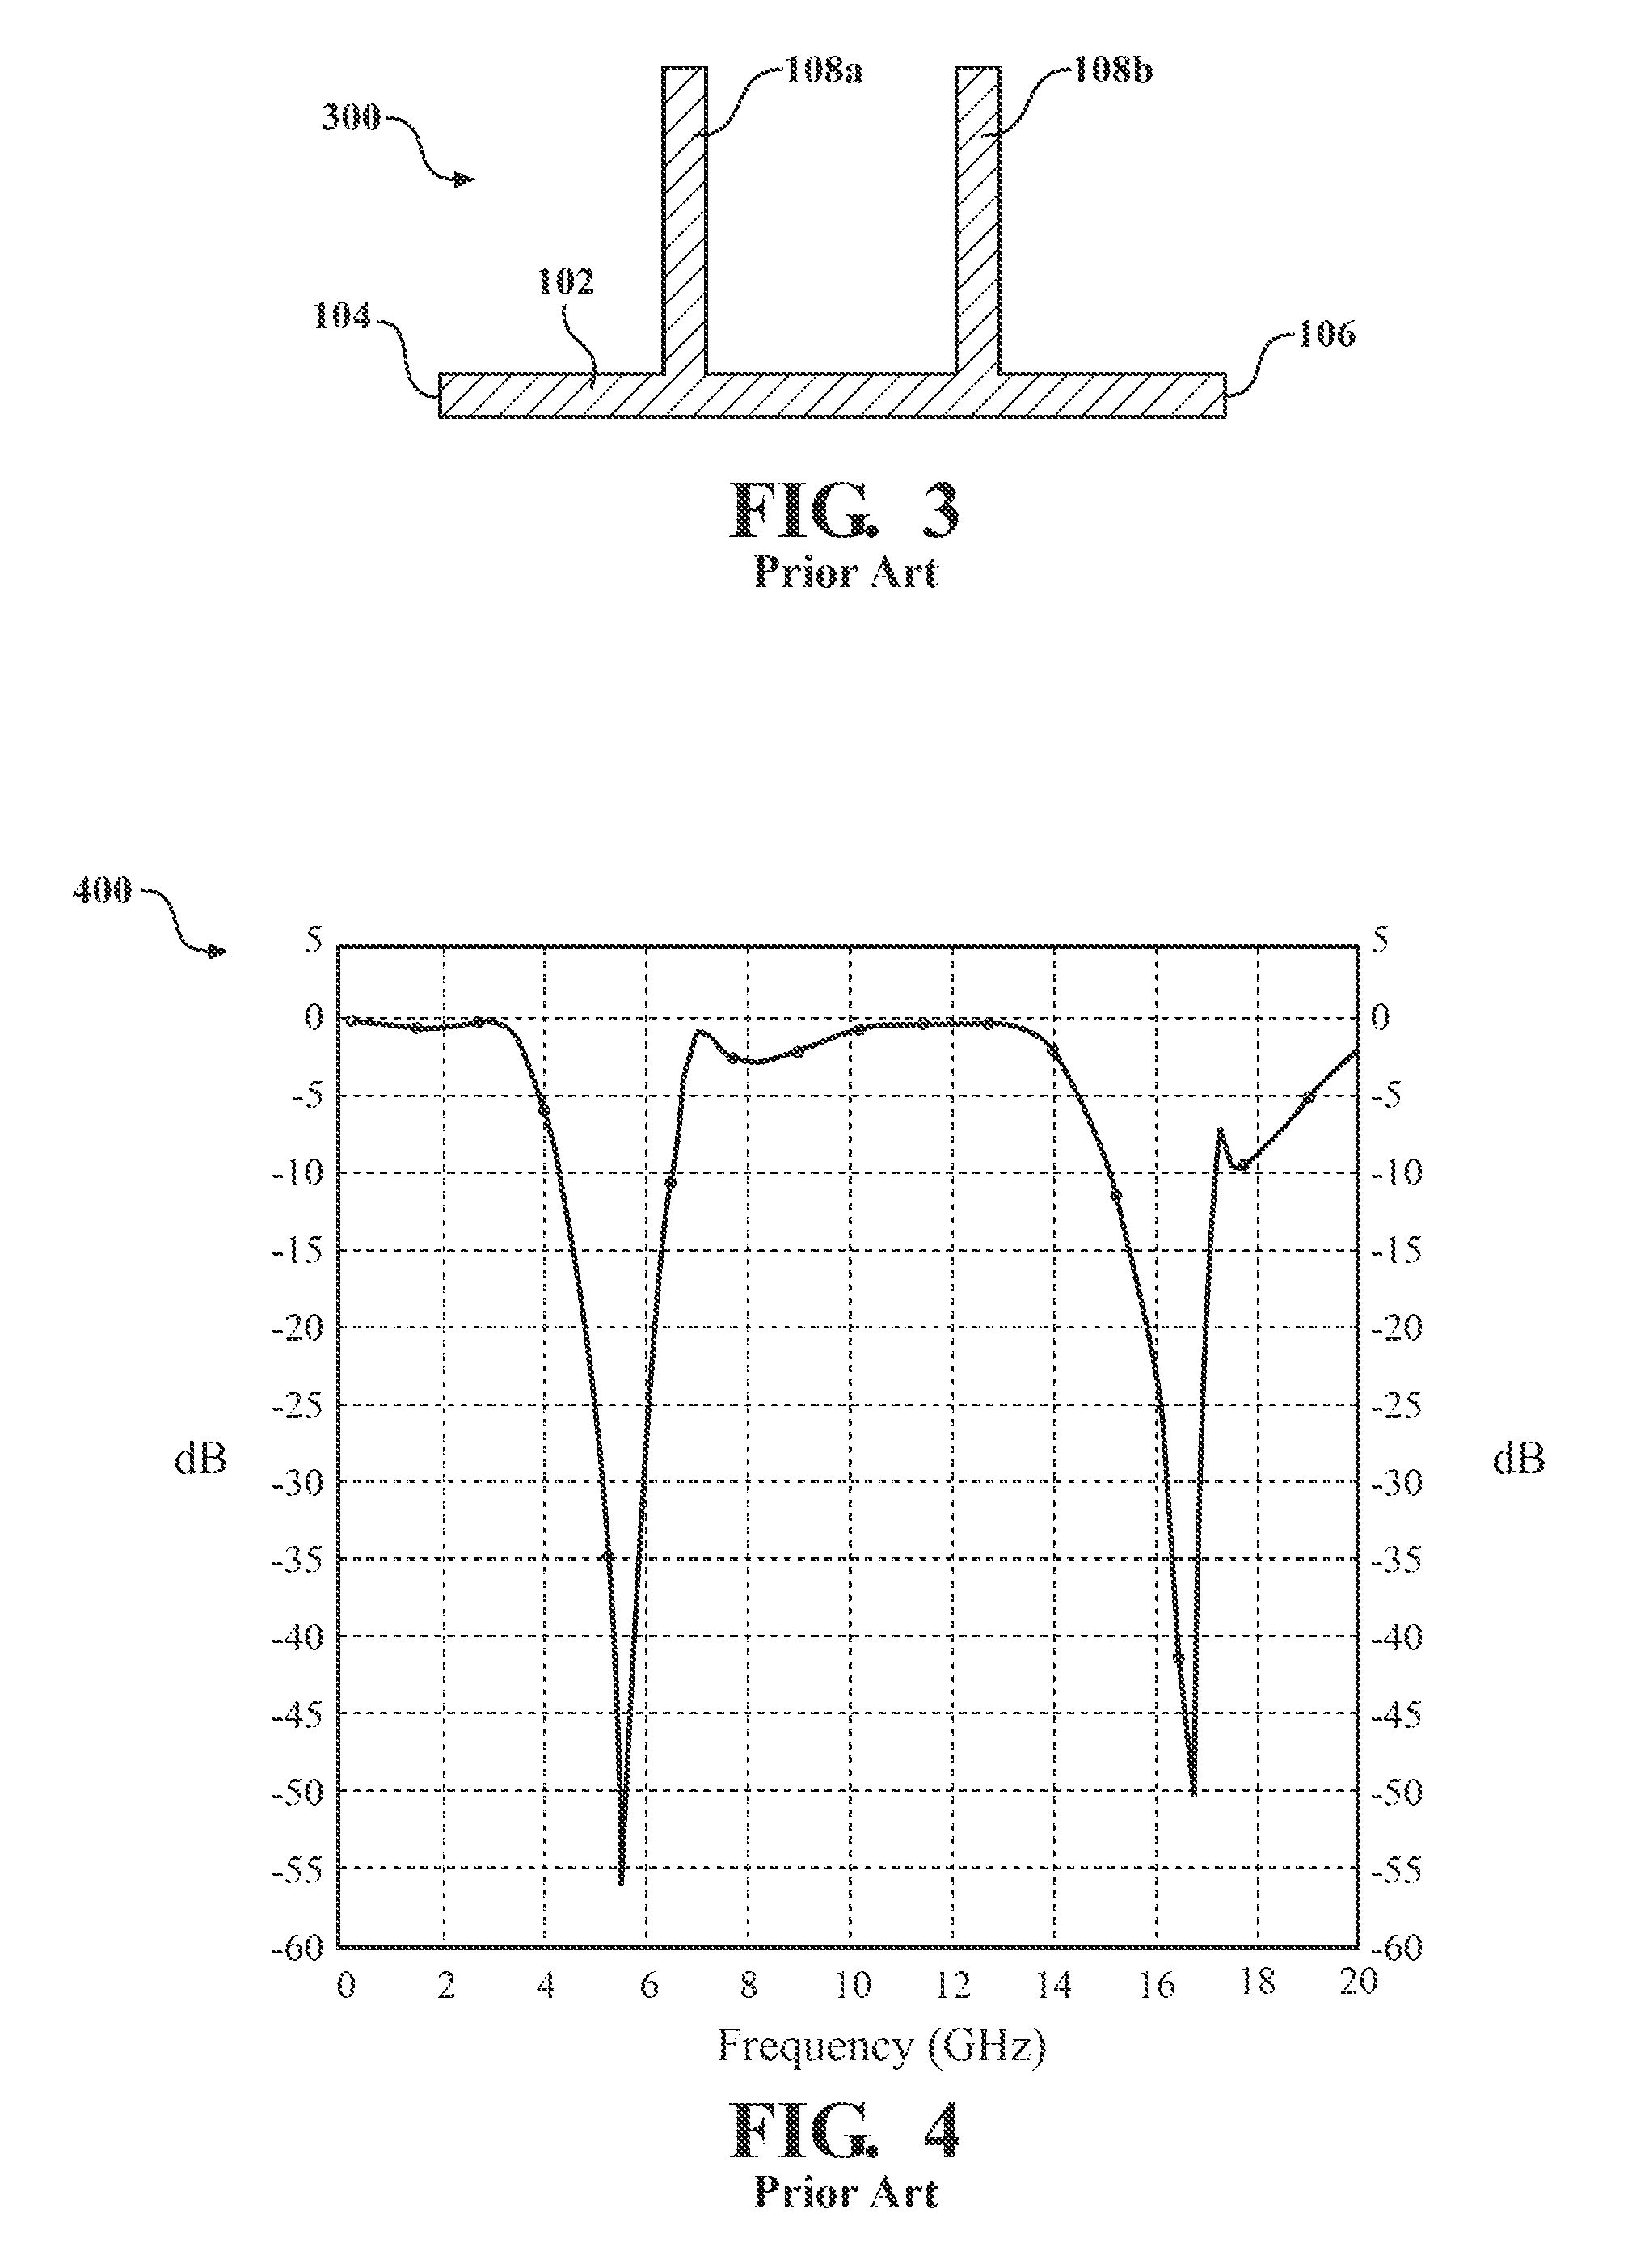
Owner:VALENTINE RES
Millimeter-band ultra-small branch line coupler
The invention belongs to the field of passive devices and particularly relates to a millimeter-band ultra-small branch line coupler, which comprises a square ring, an input port, an isolation port, anoutput port I and an output port II, wherein the input port and the isolation port are arranged on the two adjacent corners of the square ring respectively; the output port I and the output port II are disposed on the other two corners of the square ring respectively; and a wide microstrip line slice group is disposed at an intermediate position of the square ring. The branch line coupler of thepresent invention can equivalently compress a transmission wavelength, thereby reducing the size of the branch line coupler. The miniaturization of the branch line coupler is achieved without affecting the performance of a branch coupler.
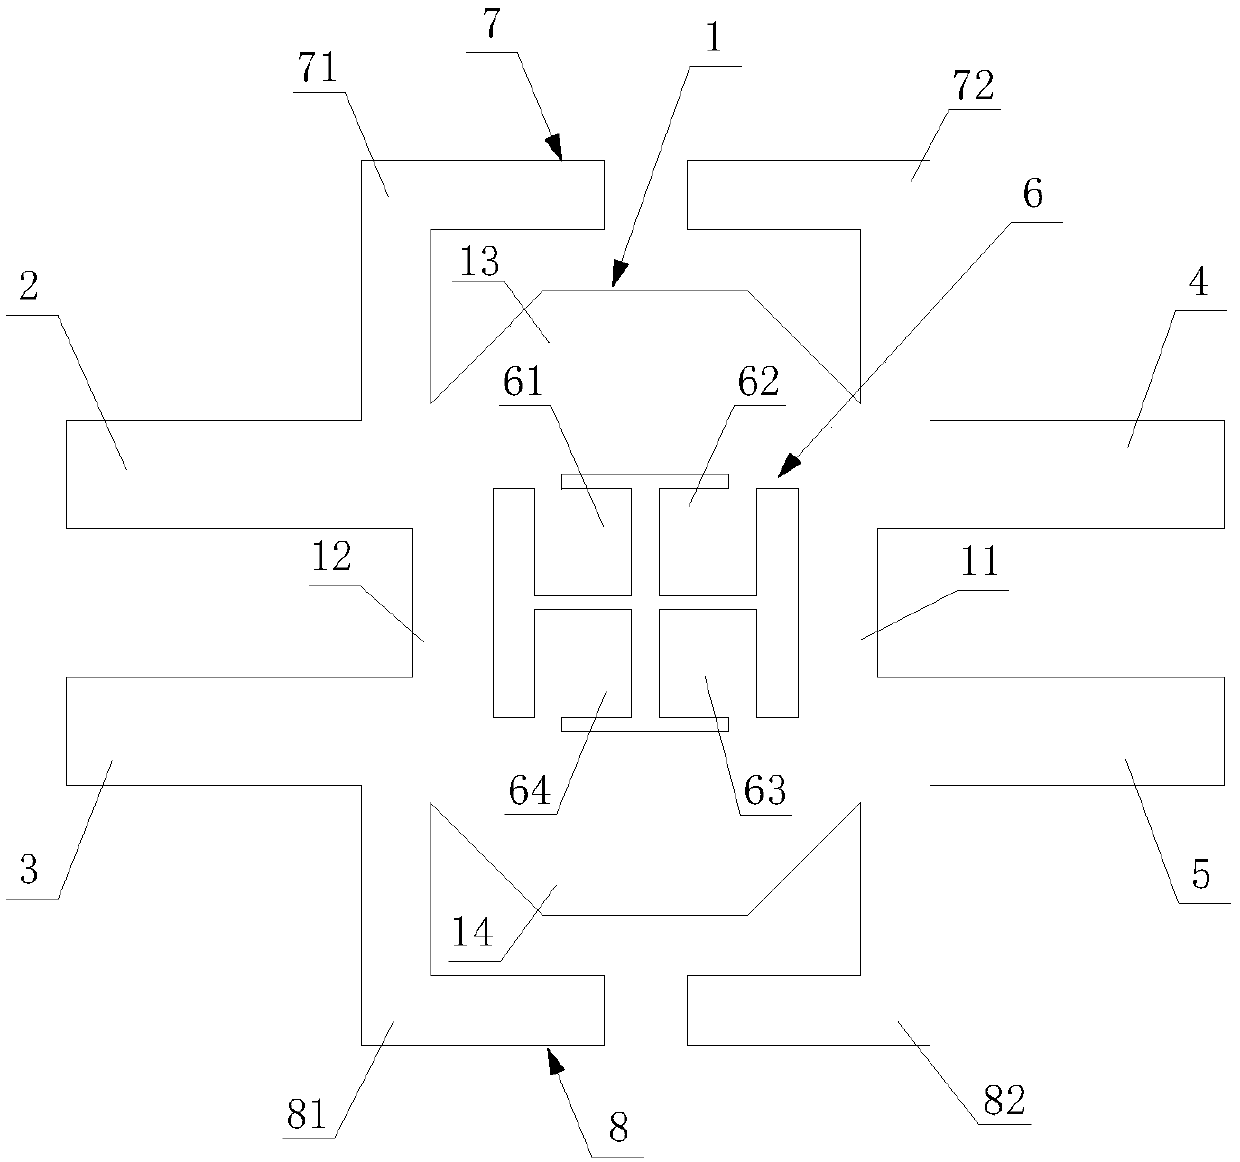
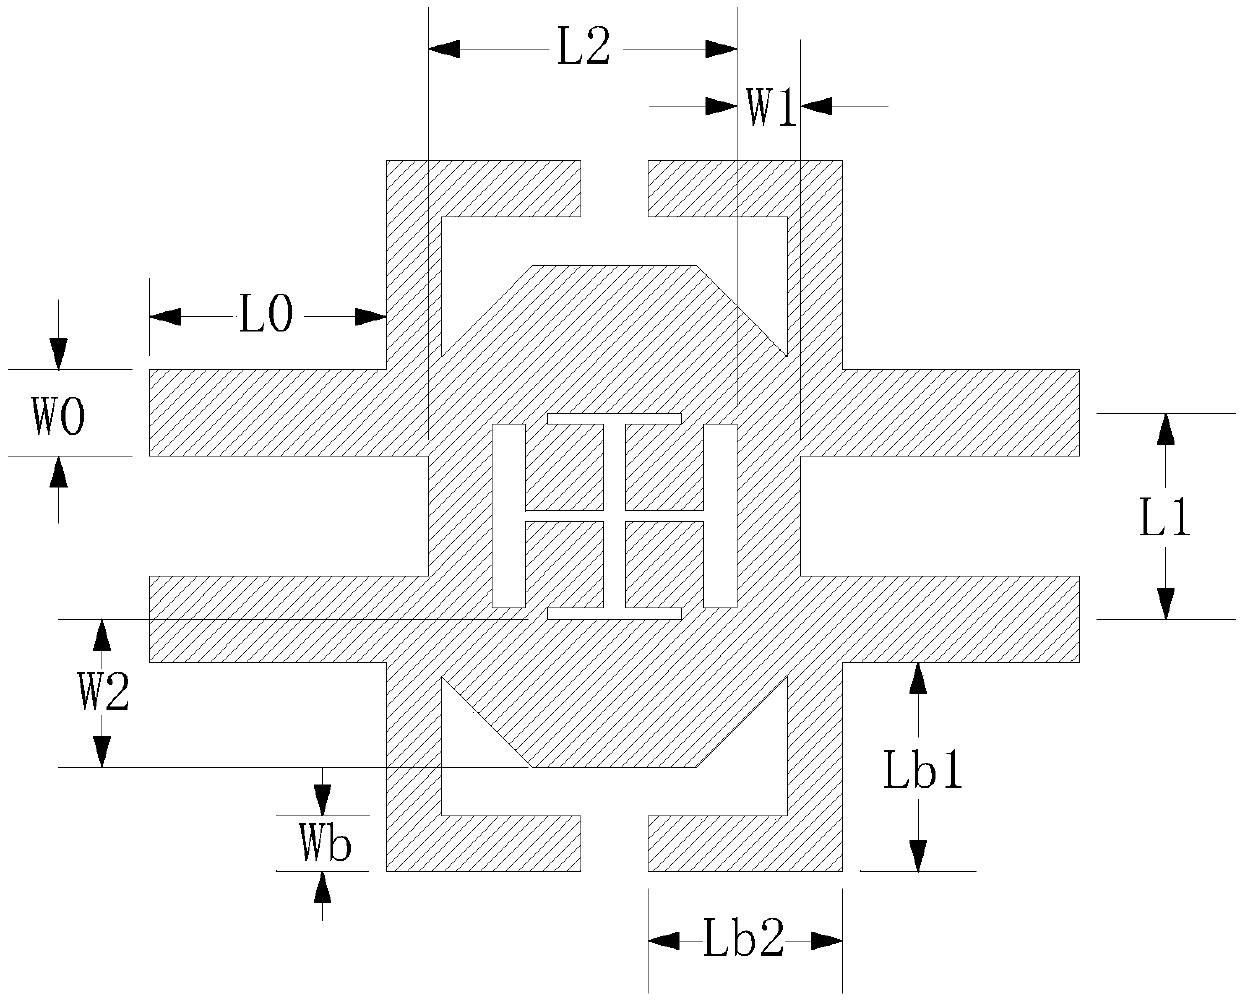
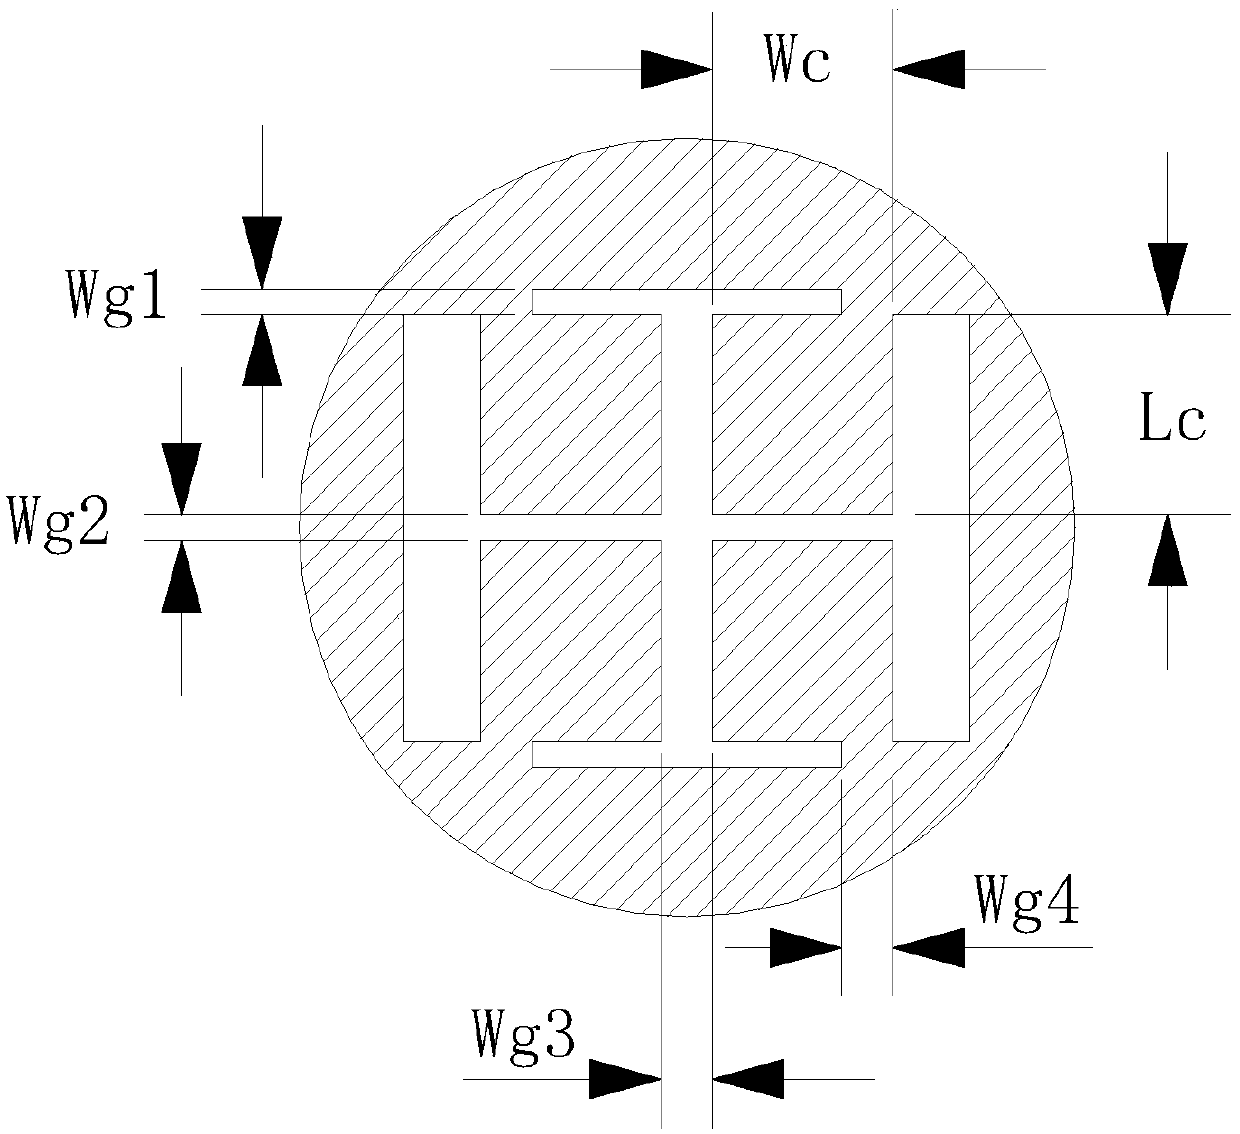
Owner:ANHUI SUN CREATE ELECTRONICS
Compact bandpass filter with no third order response
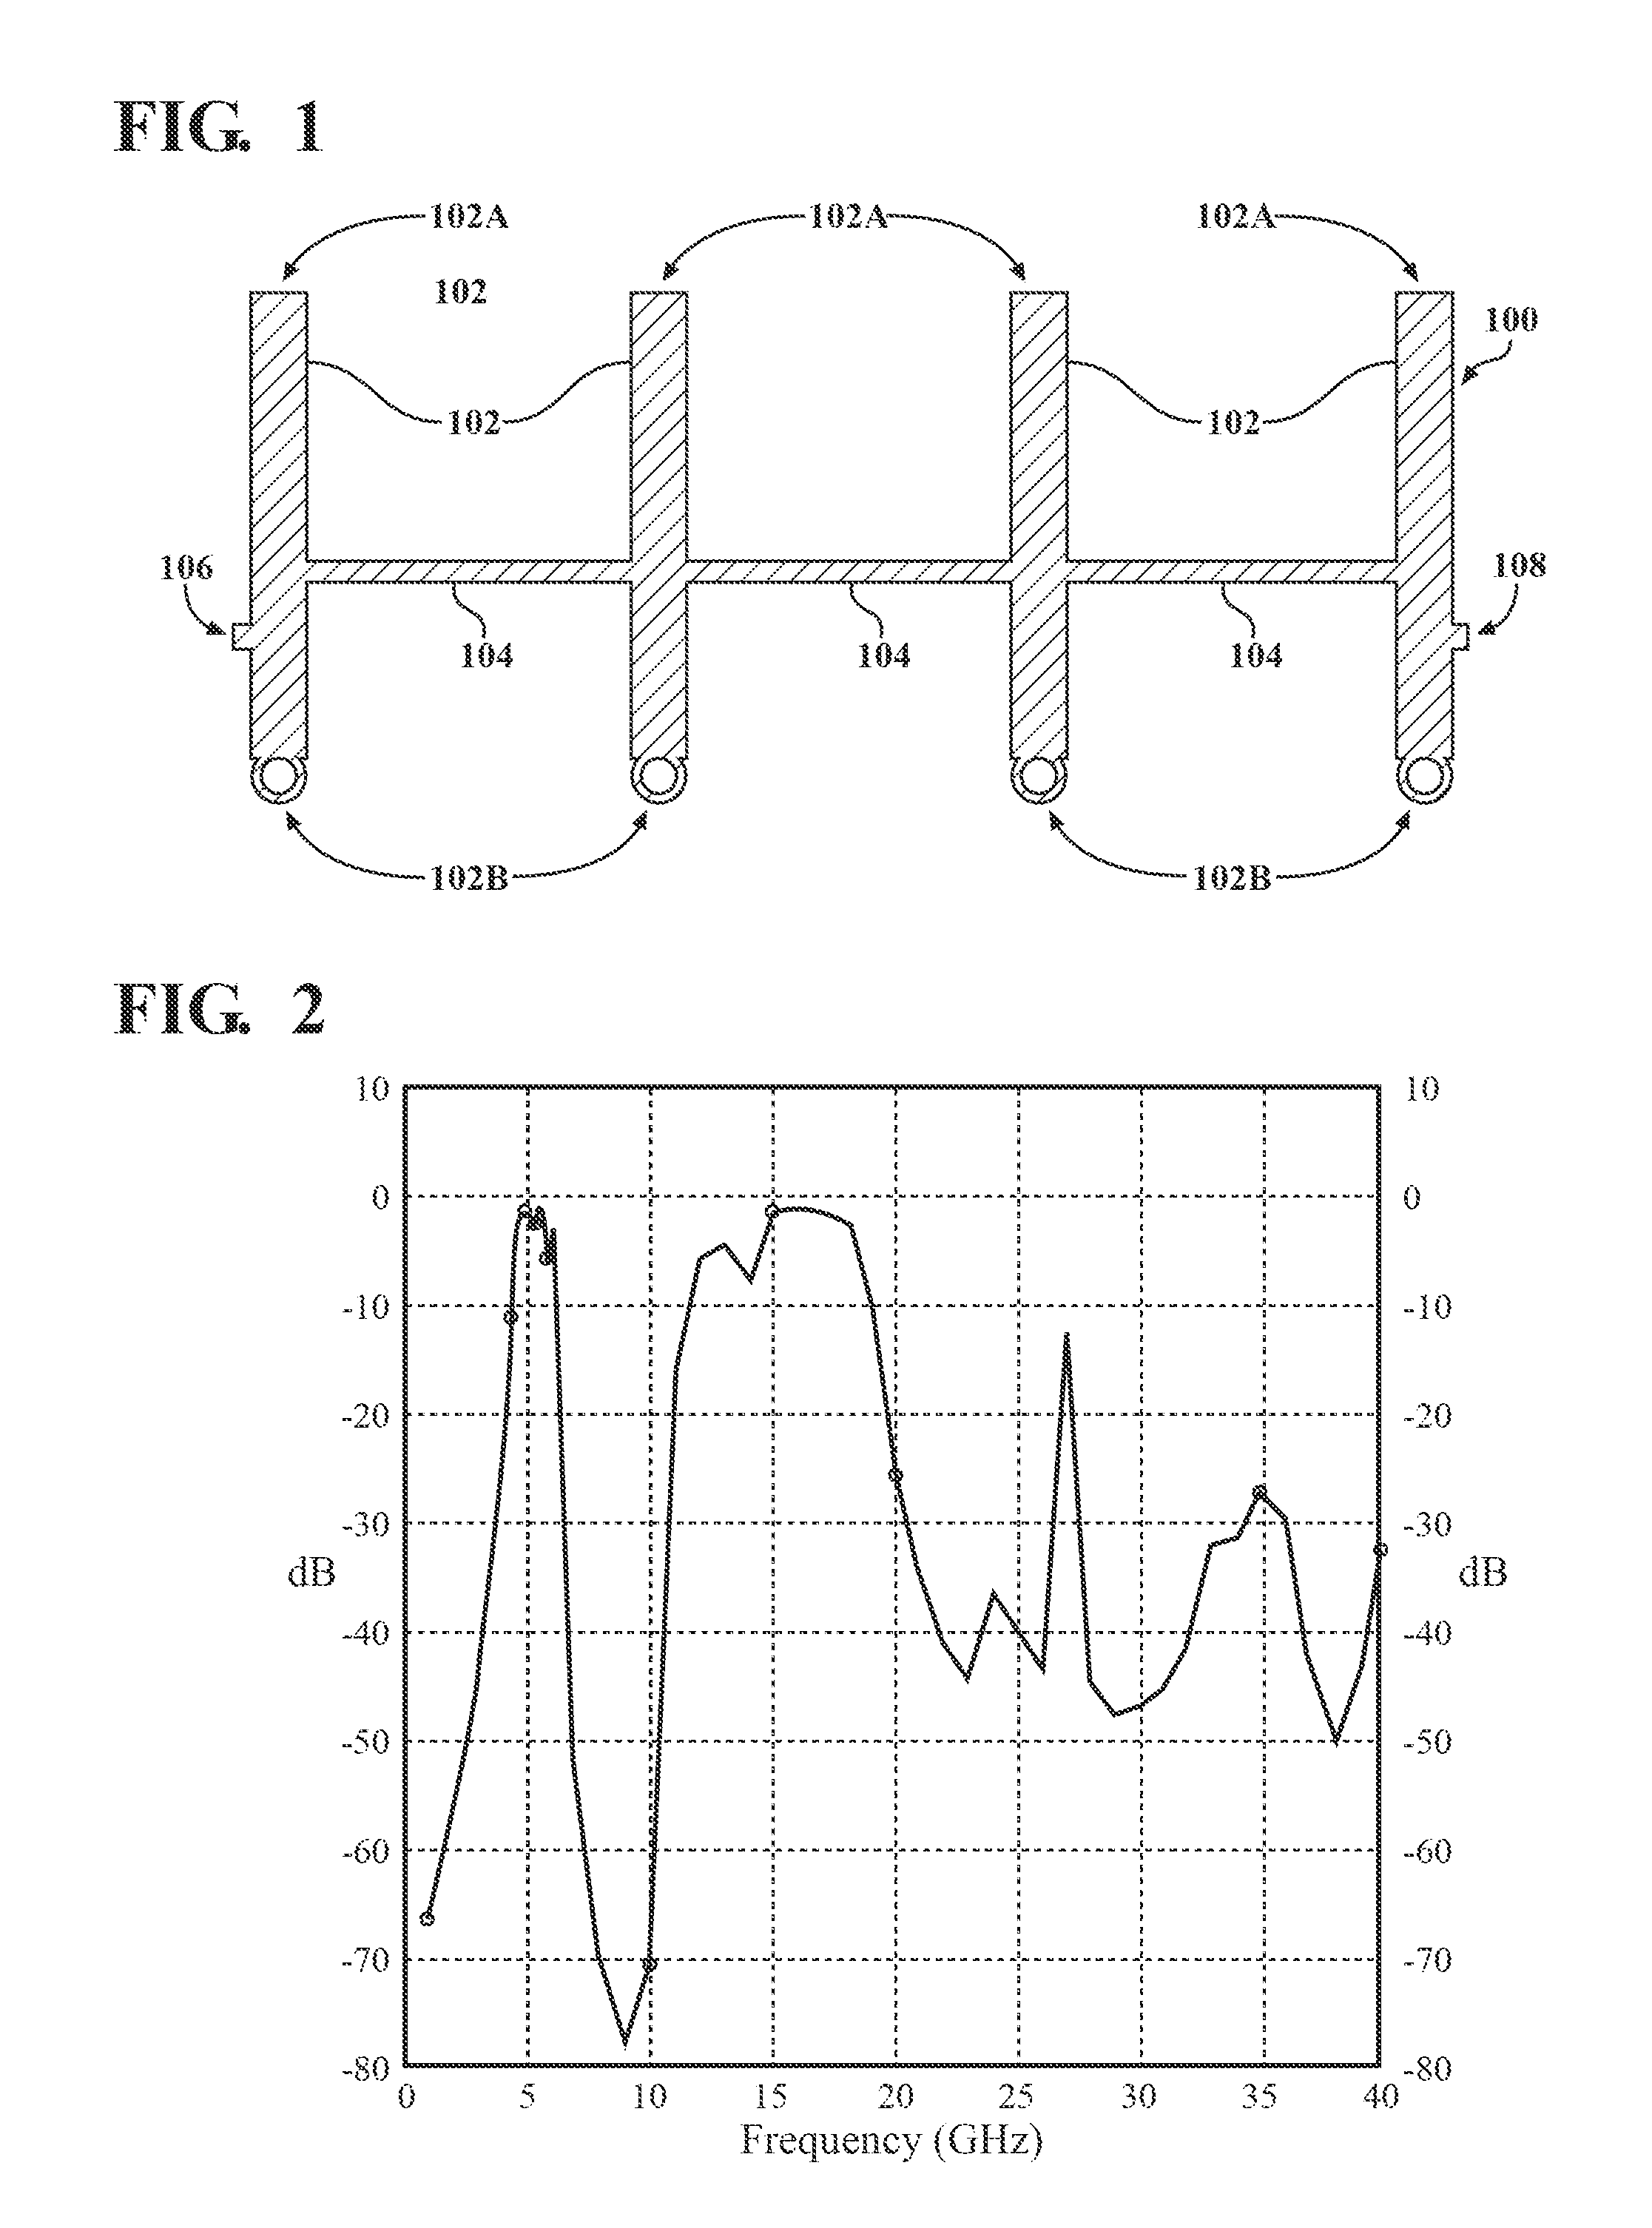
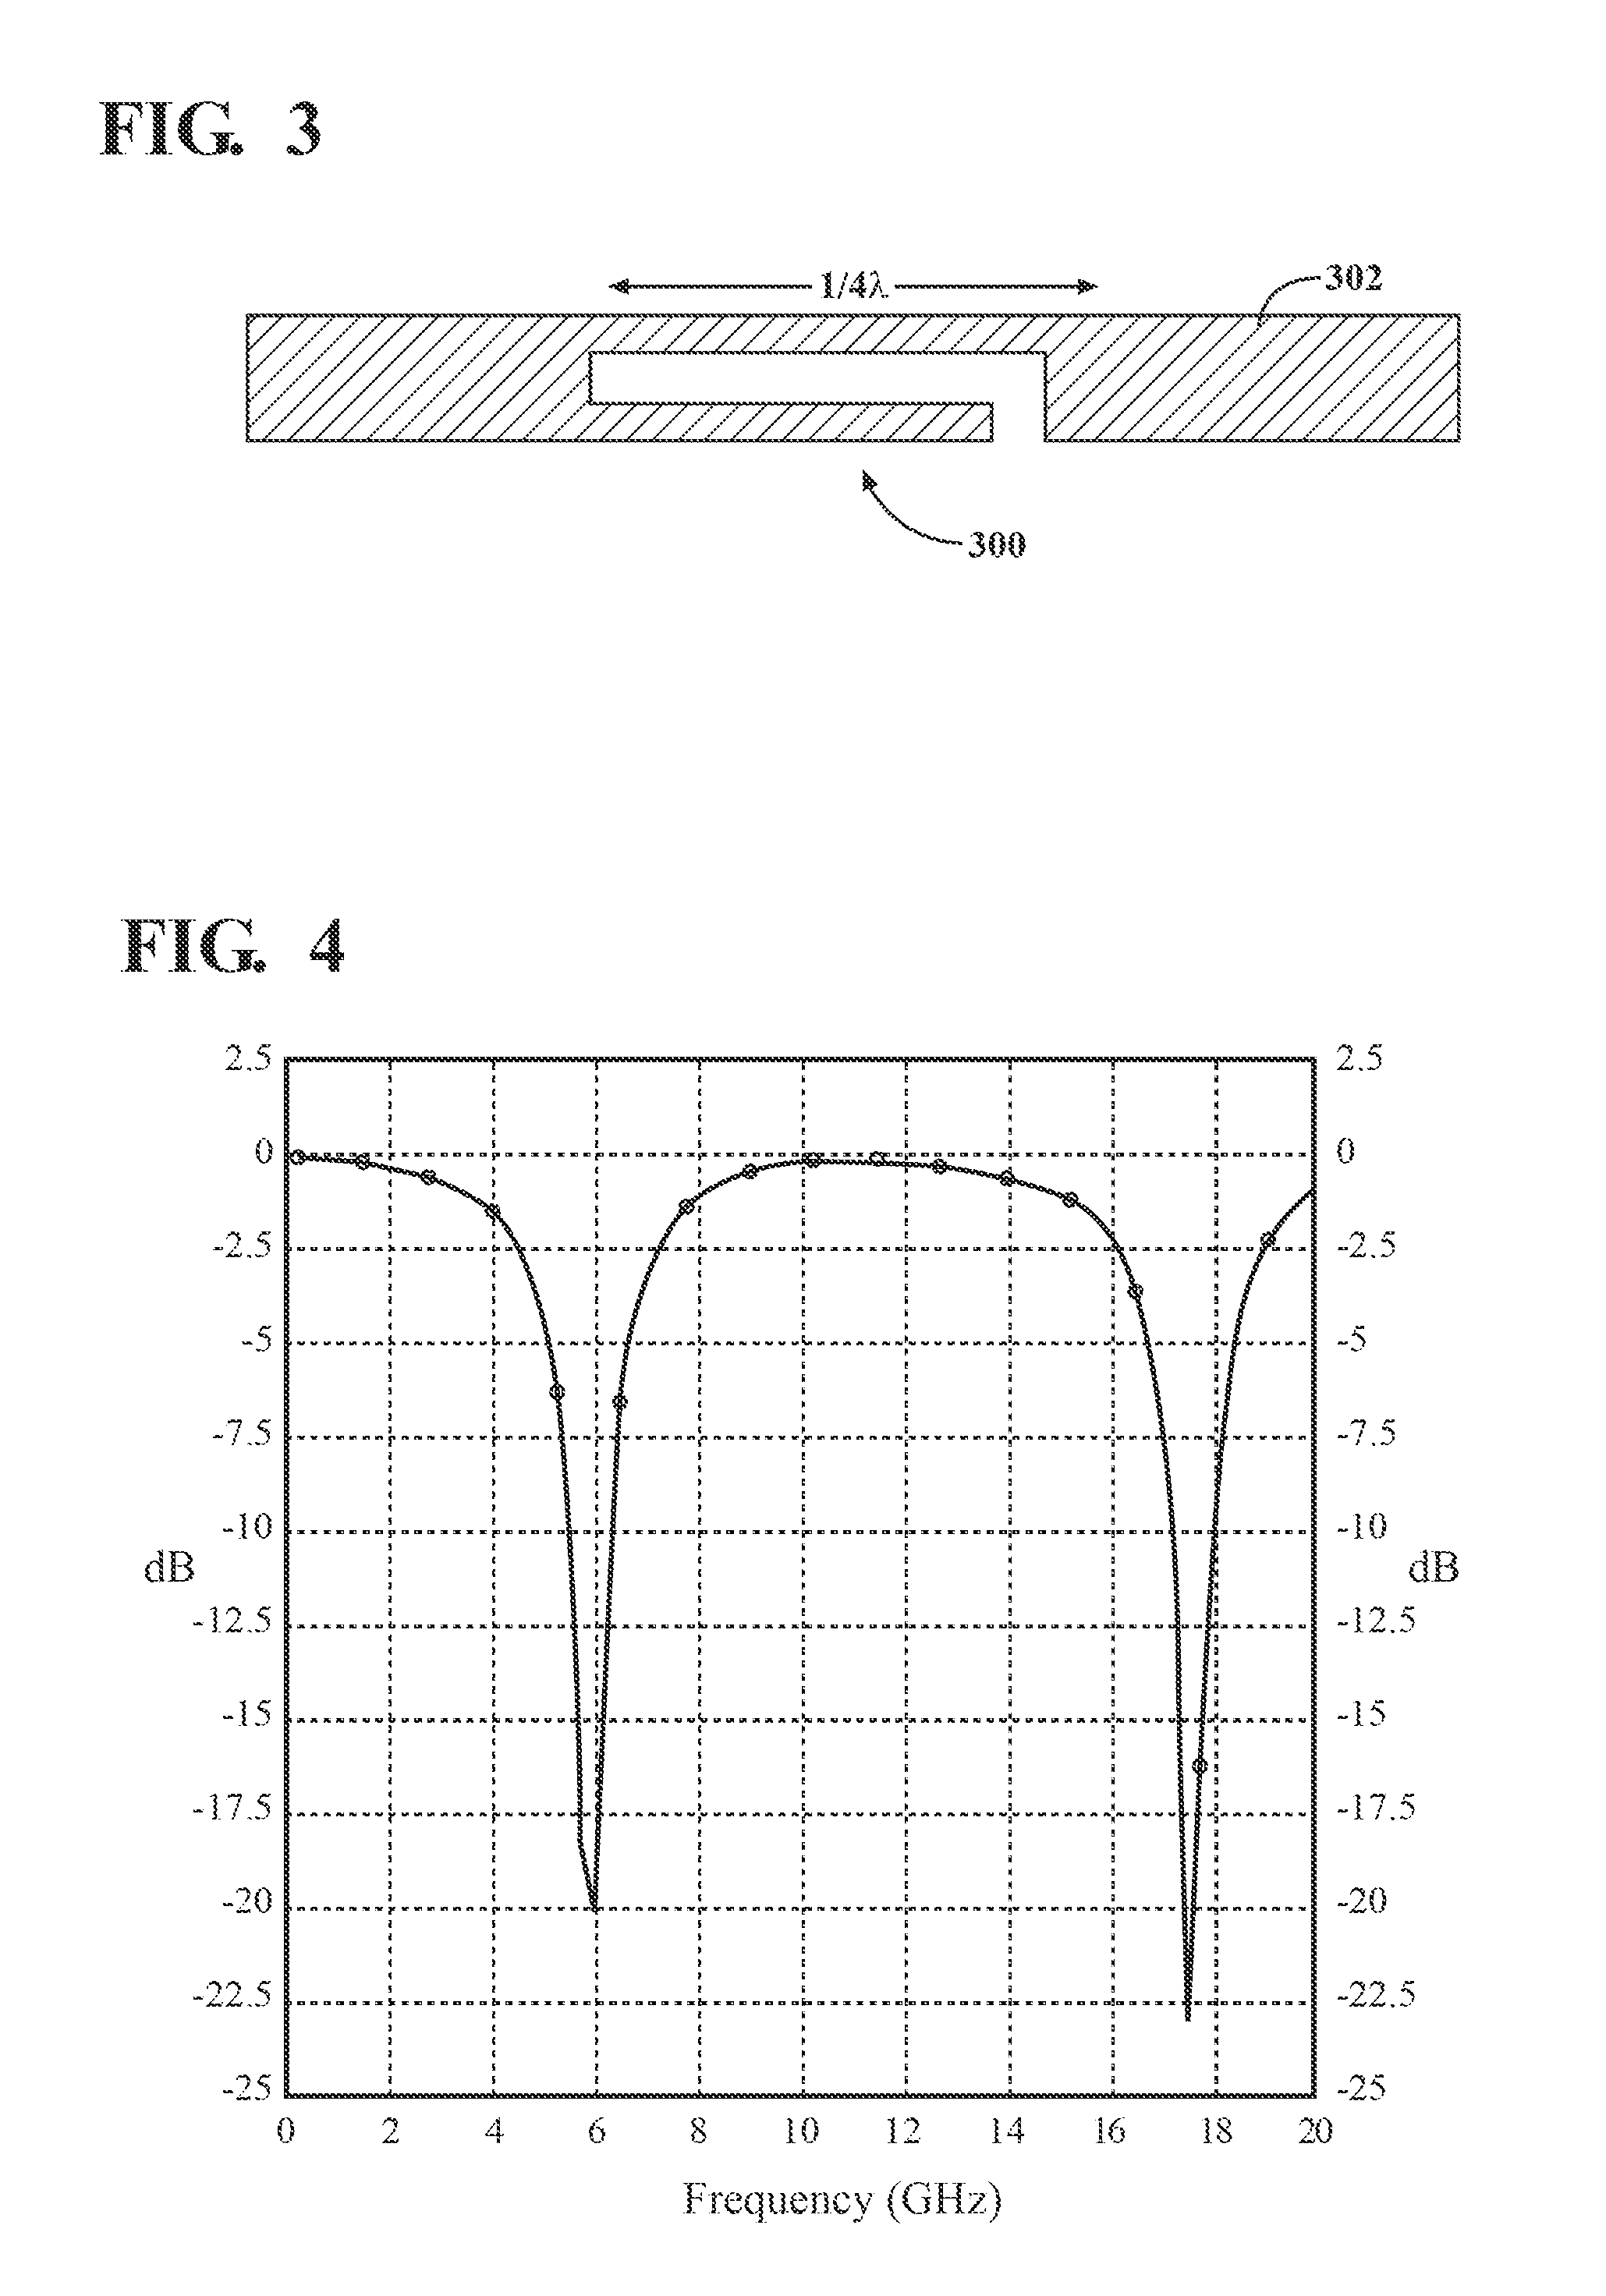
Owner:VALENTINE RES
Compact bandpass filter with no third order response
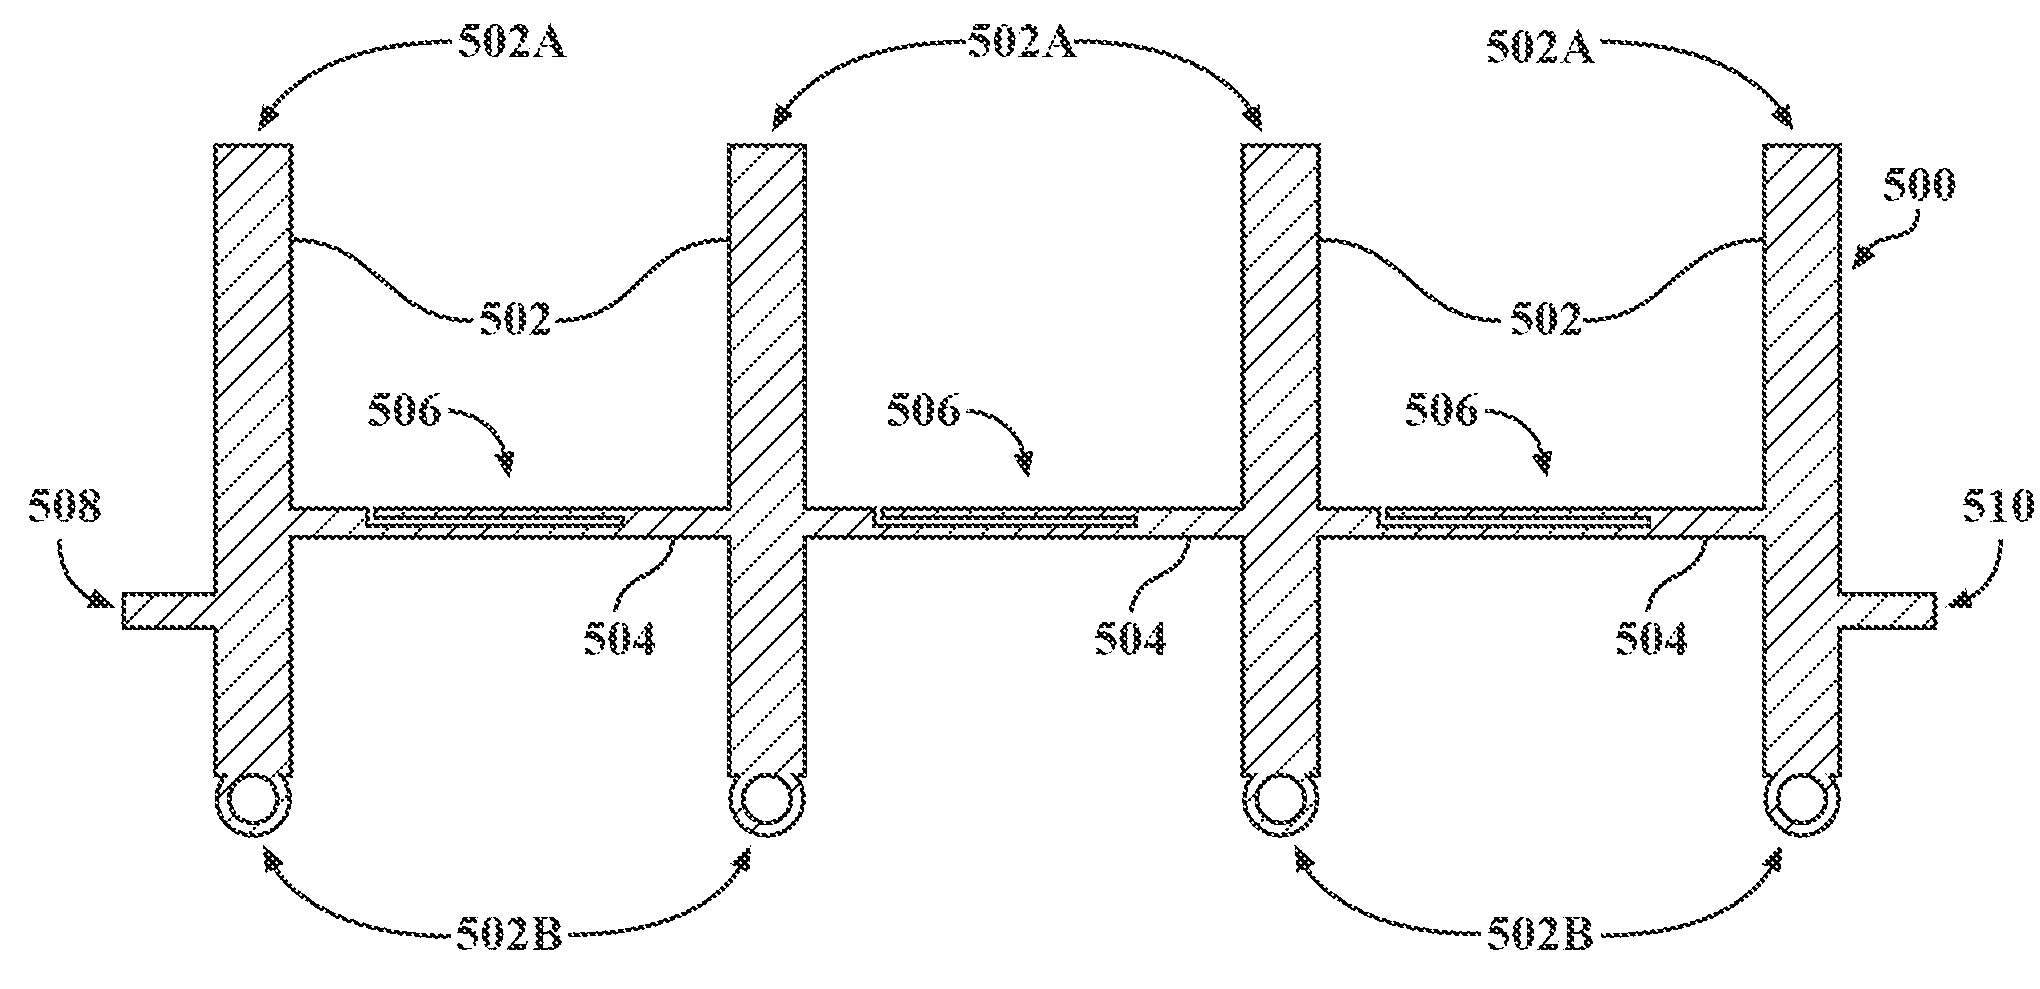
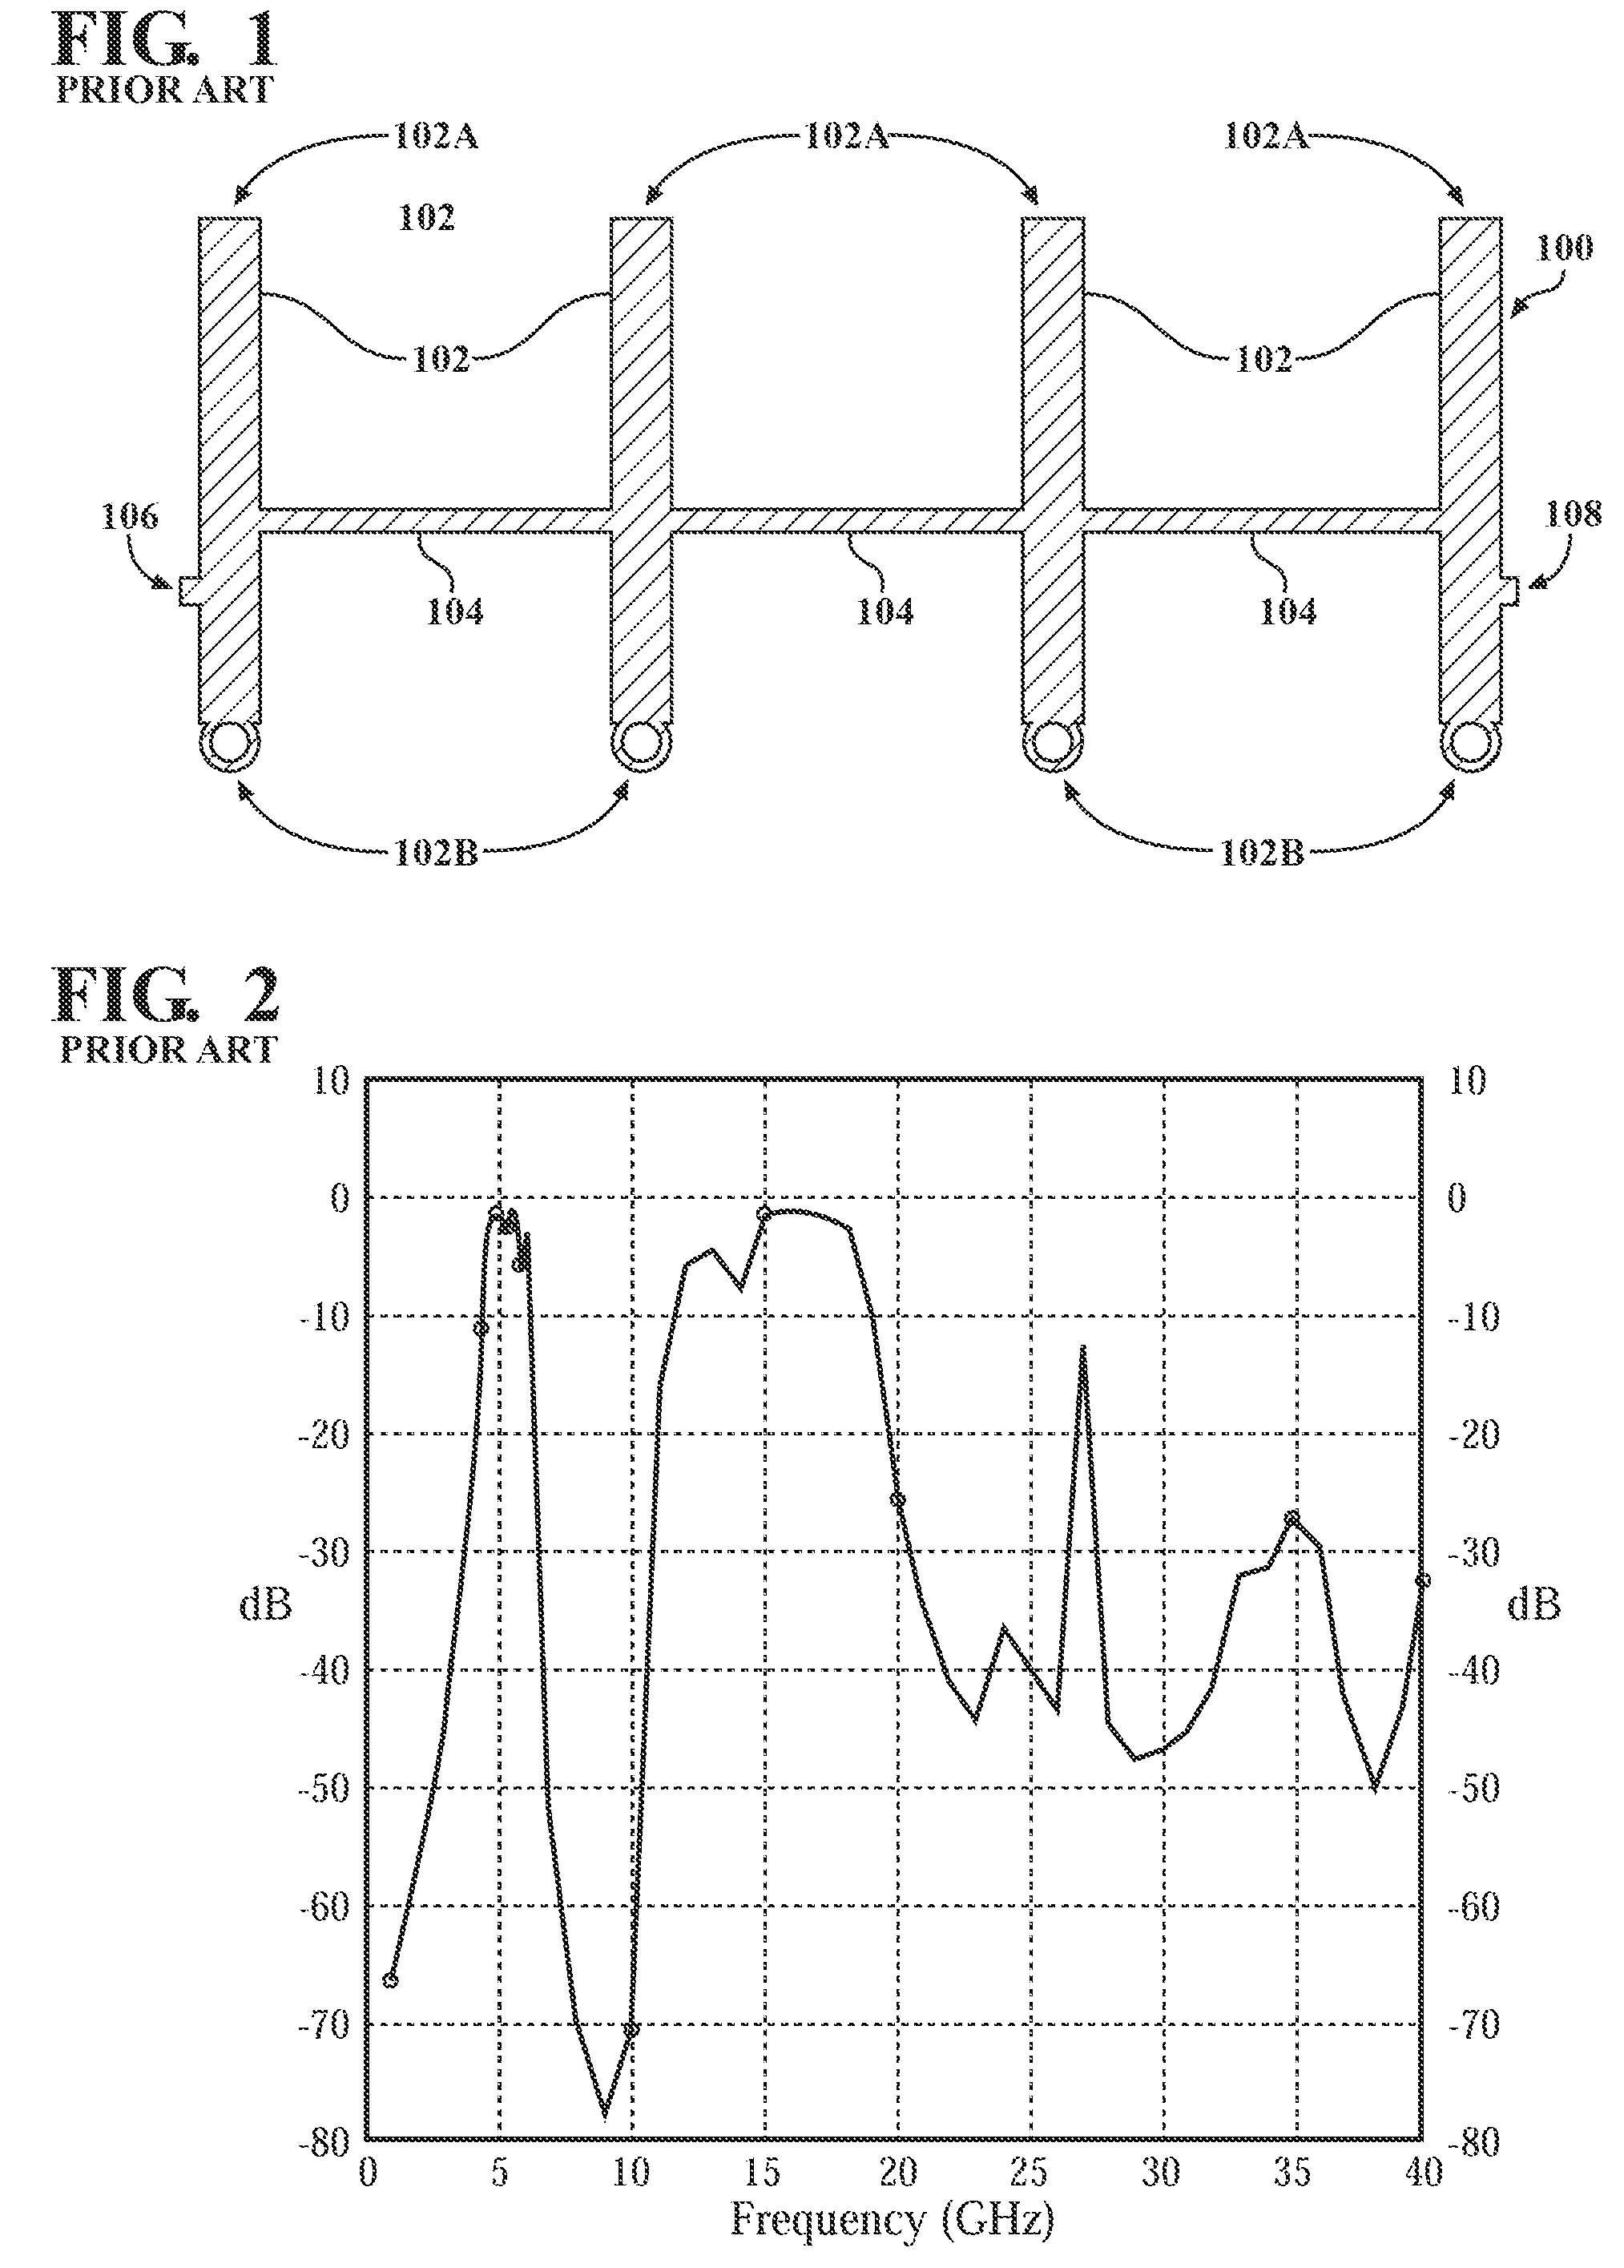
Owner:VALENTINE RES
Surface acoustic wave filter
InactiveUS6861925B2Impedence networksPiezoelectric/electrostrictive/magnetostrictive devicesSpurlineSurface acoustic wave sensor
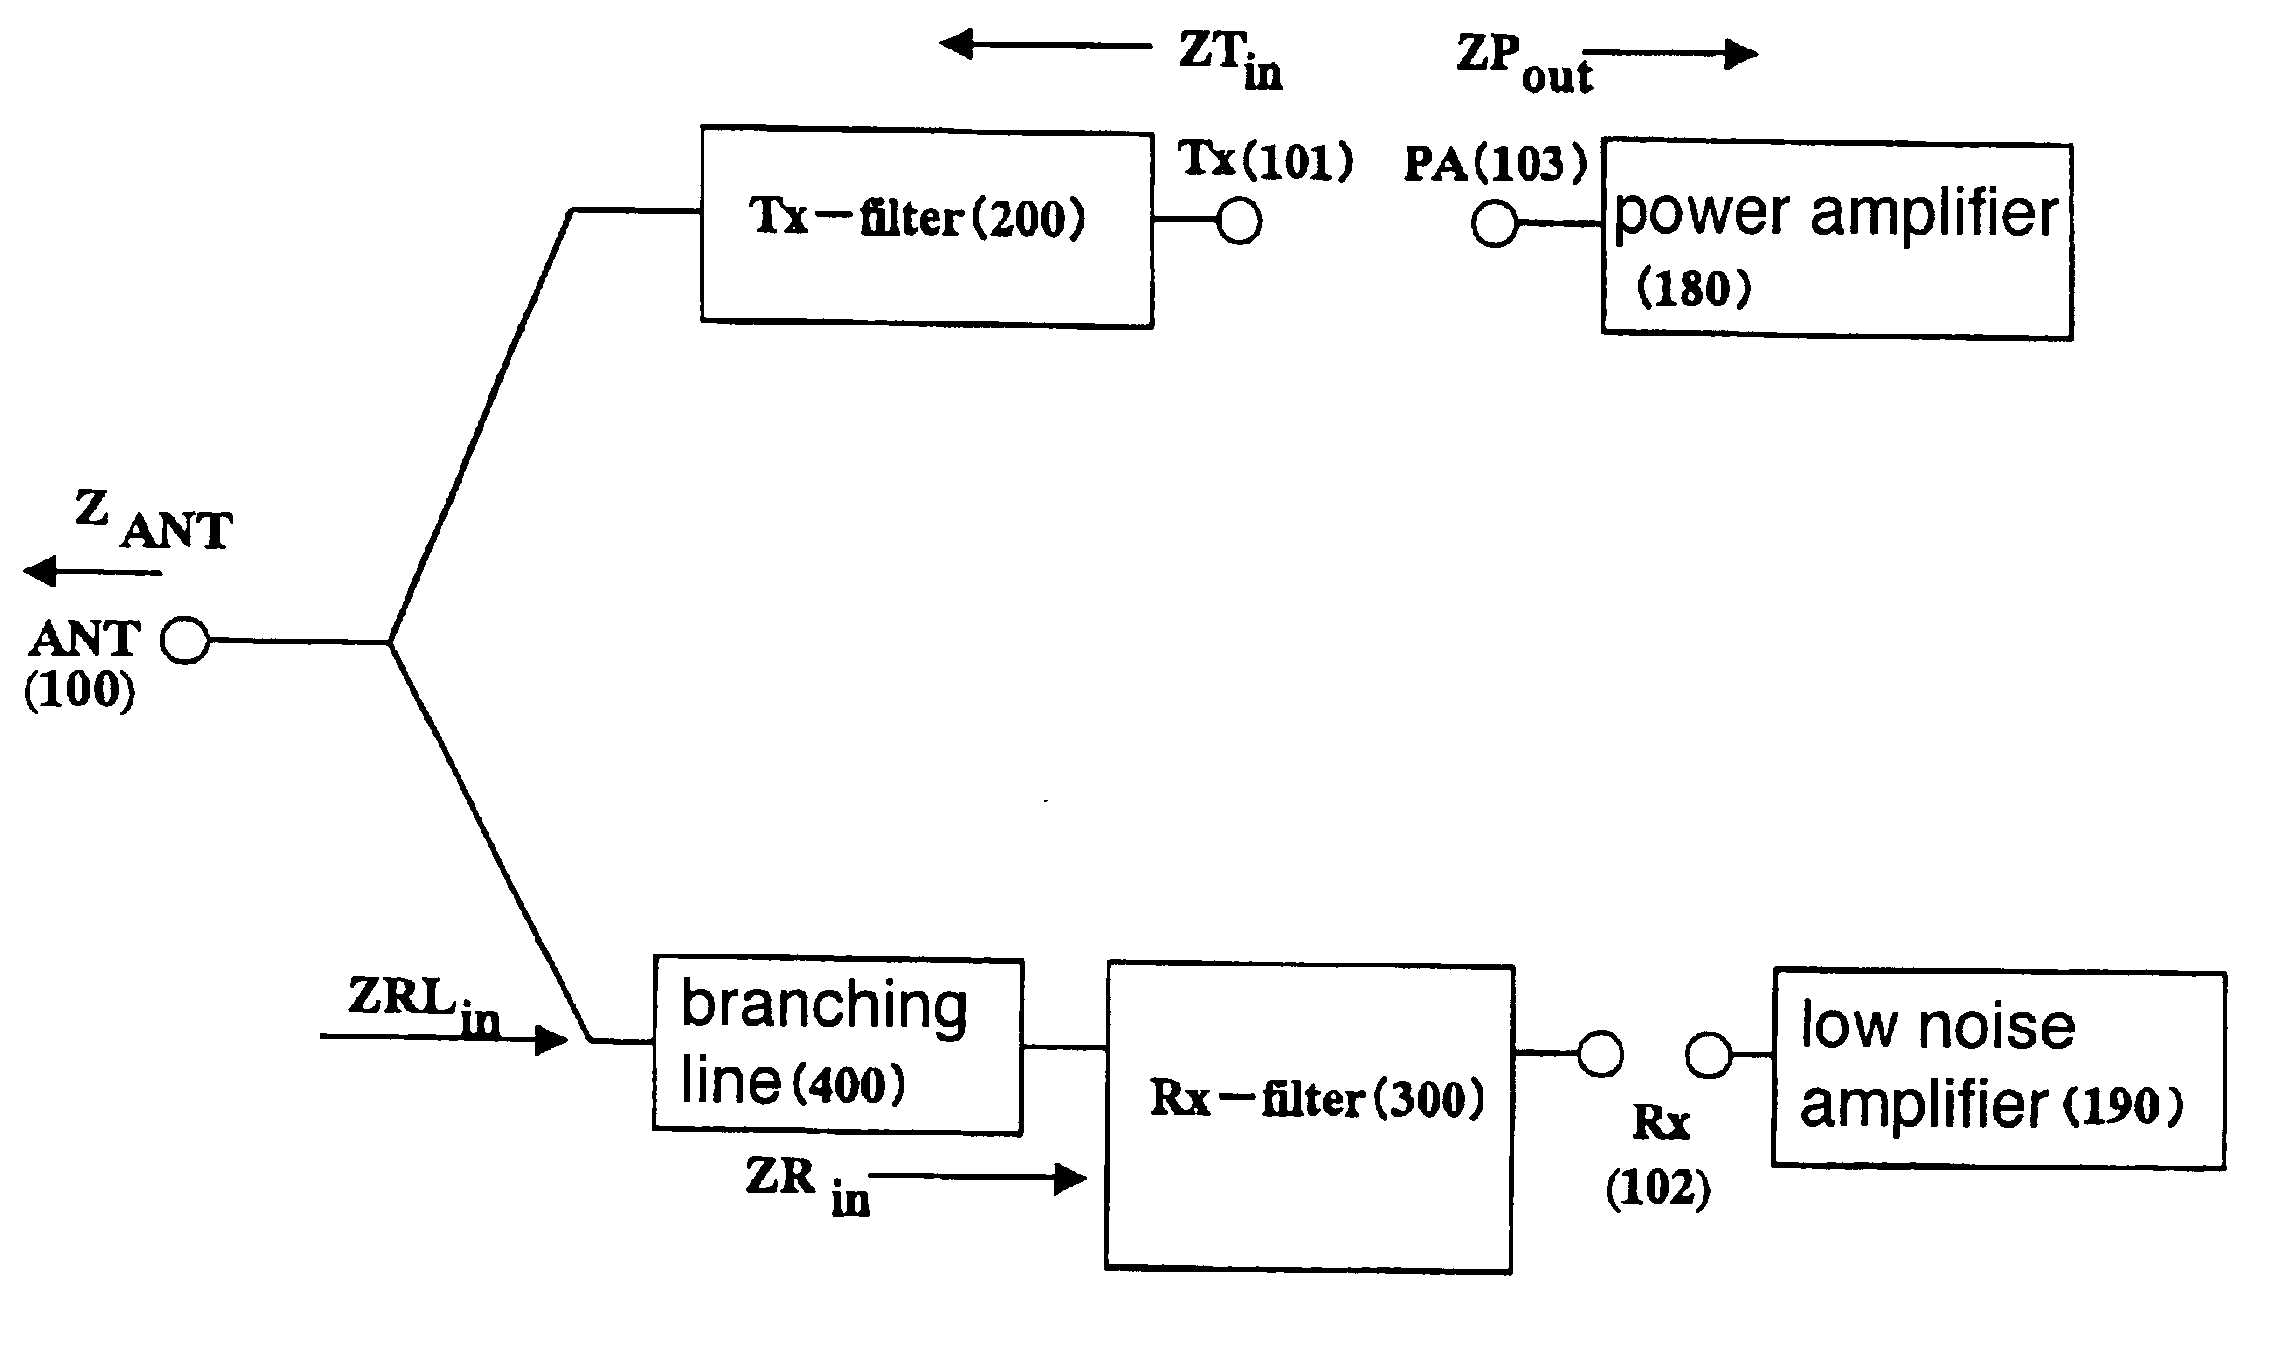
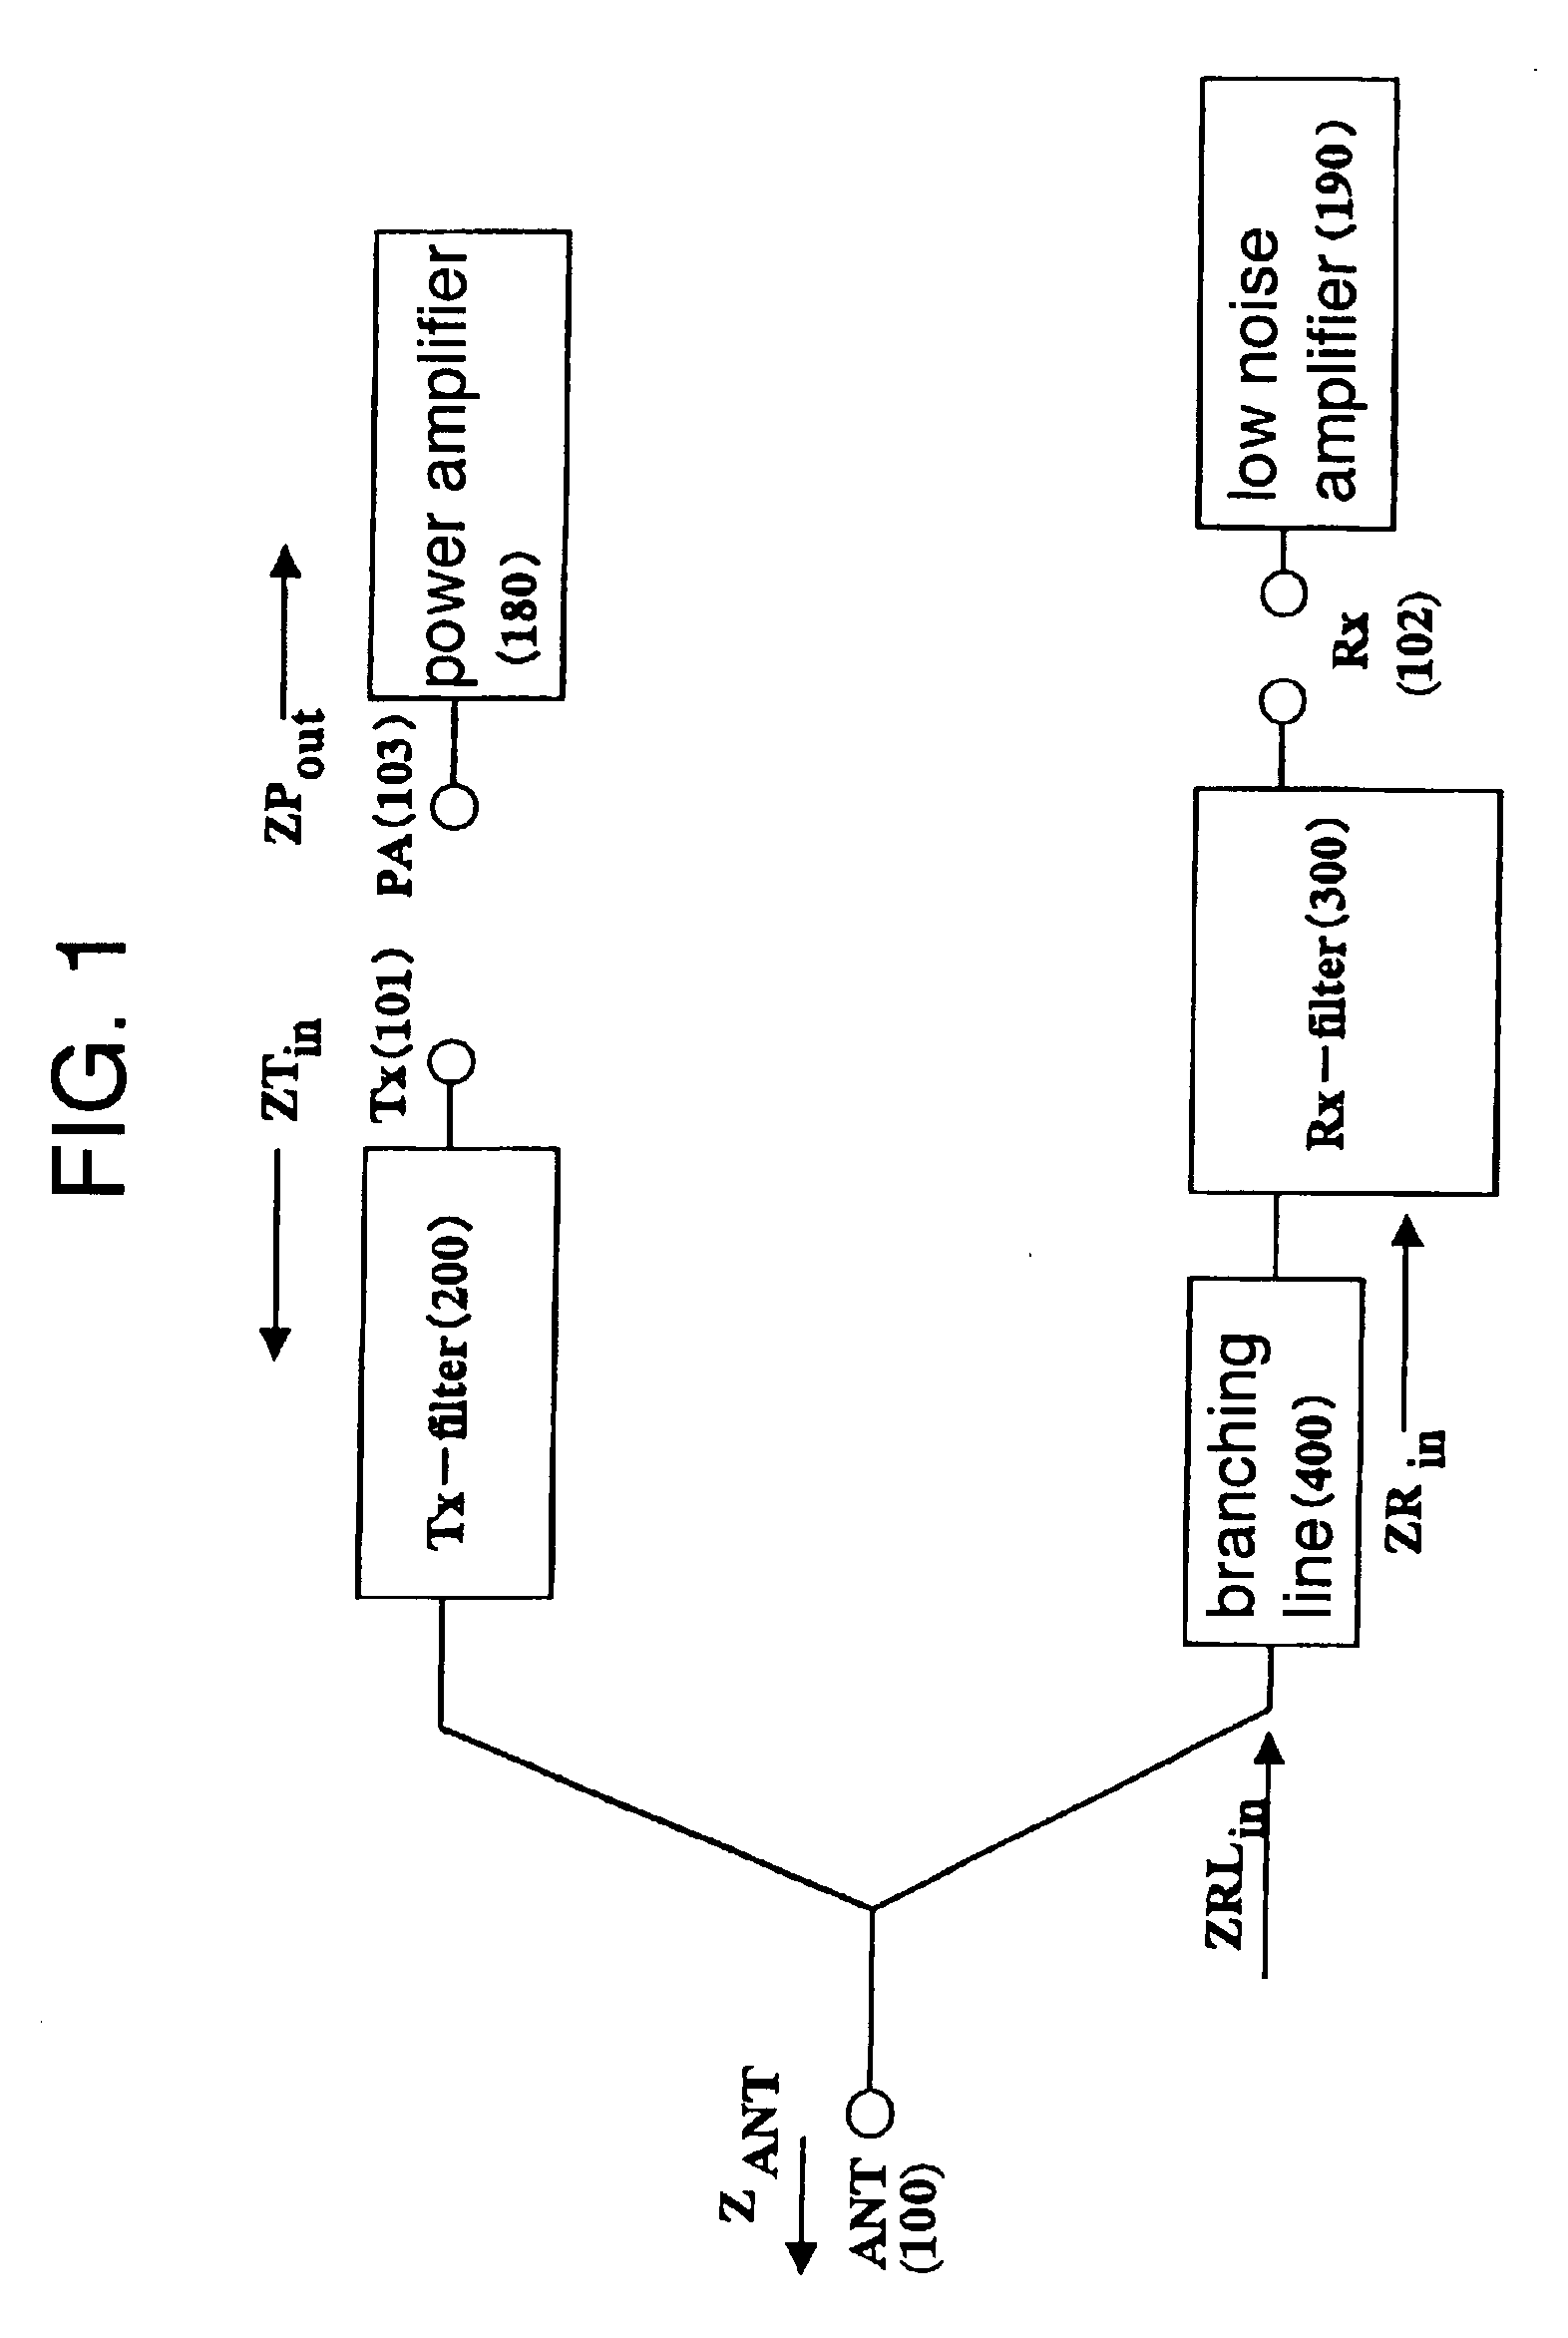
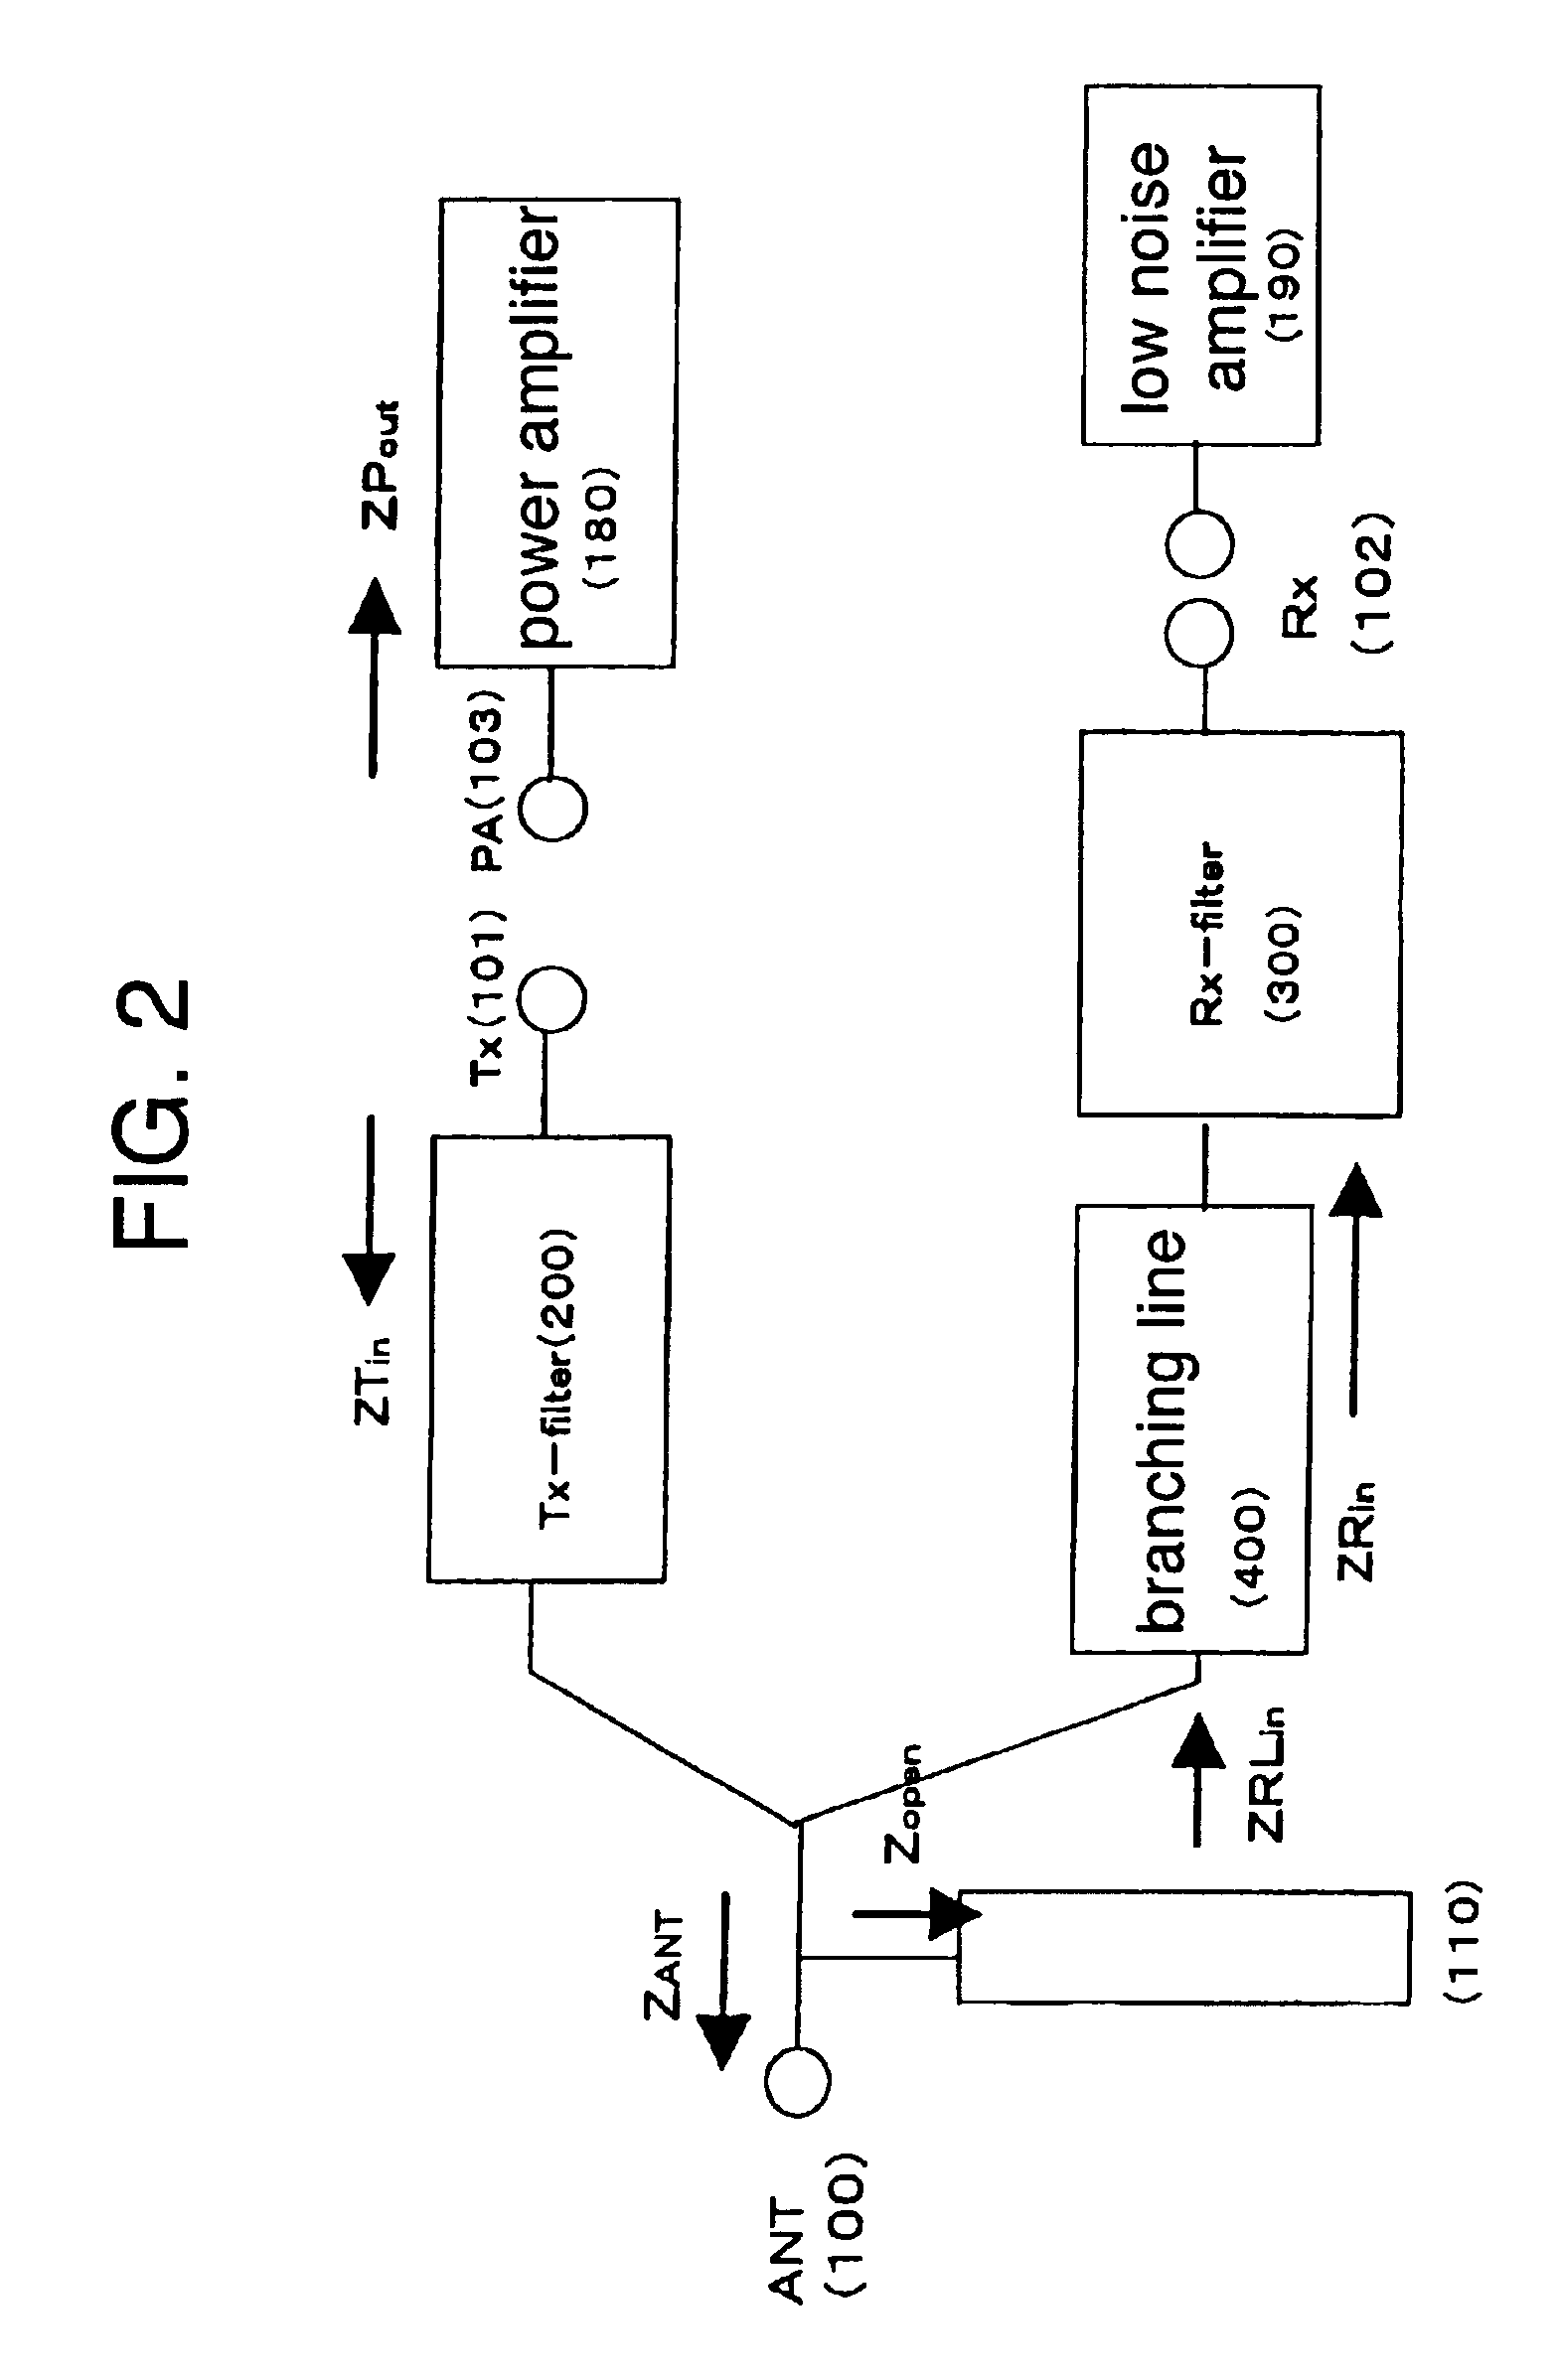
A surface acoustic wave filter includes an antenna terminal, an antenna, a transmitting filter, a branching line and a receiving filter. The antenna is coupled to the antenna terminal. The transmitting filter is coupled to the antenna terminal. The transmitting filter receives an electrical power. The branching line is coupled to the antenna terminal. The branching line has a first length that is longer than λ / 4 length so that the electrical power received by the transmitting filter when the antenna terminal is opened is smaller than when the antenna terminal is terminated, wherein λ is a wave length of a center frequency of transmitted and received bands of the surface acoustic wave filter. The receiving filter is coupled to the branching line.
Owner:INTELLECTUAL VENTURES HOLDING 81 LLC
A Two-Dimensional Reconfigurable Orthogonal Coupler
The invention discloses a double-dimension reconfigurable orthocoupler. The double-dimension reconfigurable orthocoupler comprises a dielectric plate, an improved branch coupler, a frequency modulation bias unit and a power-division-ratio adjusting bias unit, wherein the improved branch coupler adopts a matts structure and consists of a basic branch line coupler and crossed-shaped microstrip lines; the frequency modulation bias unit consists of four frequency modulation bias circuits; the power-division-ratio adjusting bias unit consists of two power-division-ratio adjusting bias circuits, wherein a first microwave signal is accessed to the input port of the basic branch line coupler; each frequency modulation bias circuit adjusts equivalent electrical lengths of series arms and parallel arms based on a first preset bias voltage and the first microwave signal; meanwhile, each frequency modulation bias circuit adjusts equivalent impendence of the parallel arms based on a second preset bias voltage and the first microwave signal; and the output port outputs a second microwave signal with a preset center frequency and preset power-division ratio. Based on the double-dimension reconfigurable orthocoupler, continuous adjustment of the center frequency and the power-division ratio is realized, and the purposes of reconfigurable center frequency and power-division ratio, signal quadrature output and easy processing are achieved.
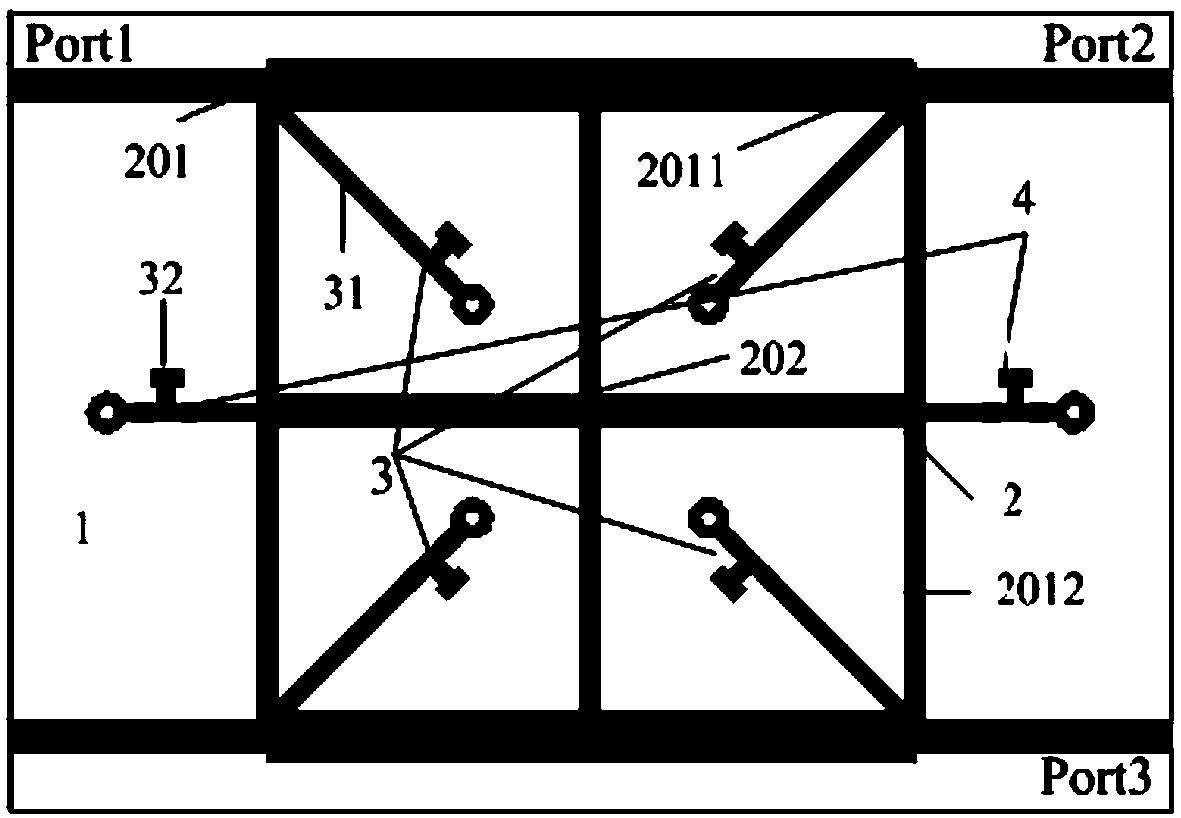
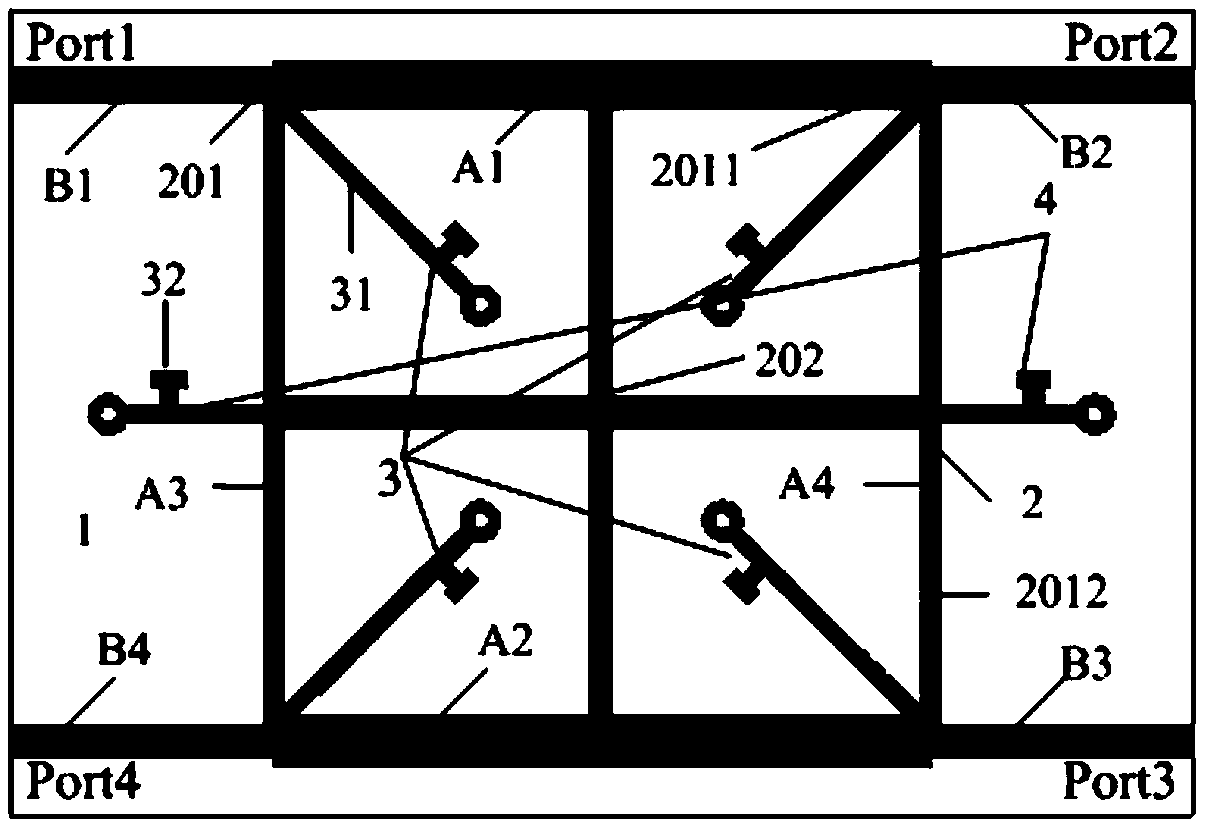
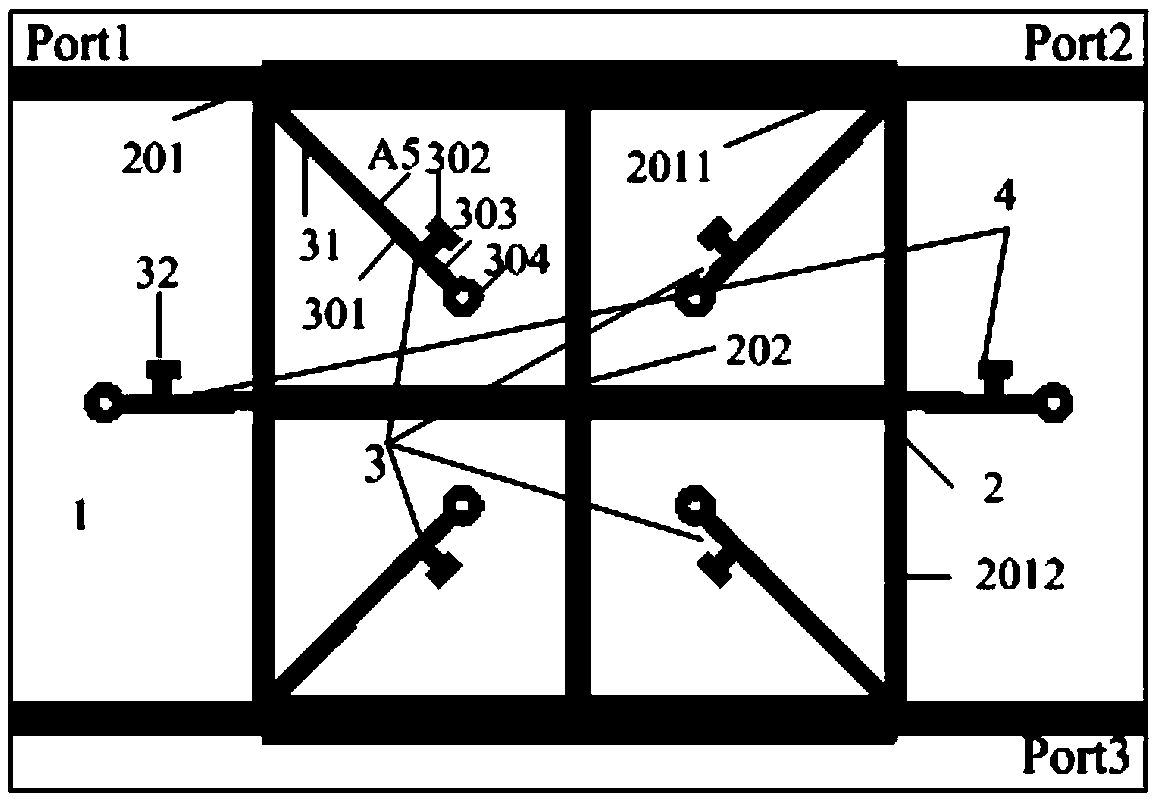
Owner:GUANGDONG UNIV OF TECH
Novel ultra wide band (UWB) Wilkinson power allocator
InactiveCN108461886AAchieving Ultra-Wideband PerformanceSmall sizeCoupling devicesSpurlineLength wave
The invention proposes a novel ultra wide band (UWB) Wilkinson power allocator. The novel UWB Wilkinson power allocator is characterized in that an overlapped butterfly-shaped stub line is arranged oneach one fourth wavelength branch of a power divider to build a new structure, and a resistor is connected between the overlapped butterfly-shaped short stub line on each branch and an output port ofthe power divider and is used for isolation. Compared with a traditional structure, the structure has the advantages that the size is only 18 millimeters by 16 millimeters, and the circuit lengthes of the two one fourth wavelength transmission lines are shorter; the bandwidth is expanded by connecting two short lines at an arbitrary side of each transmission line to form the butterfly-shaped stubline and adjusting radius, width and angle of the stub line; meanwhile, the structure is compact and miniature by changing the overlapped butterfly-shaped stub line on layout; and simulation and testresults of the UWB power allocator are favorably consistent.
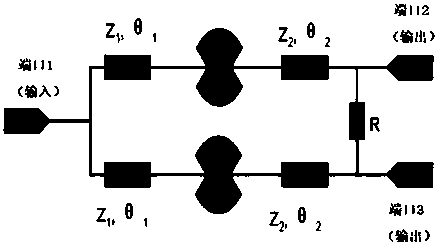
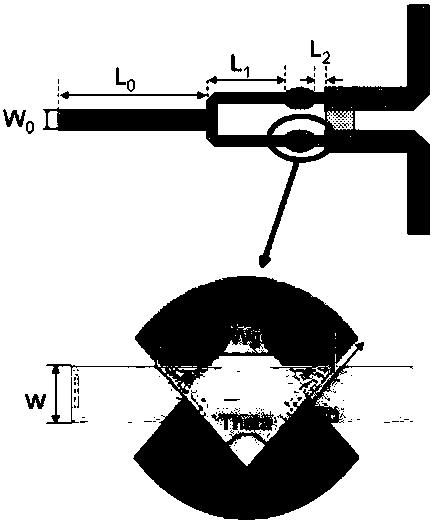
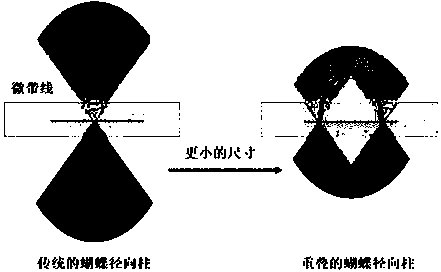
Owner:NANJING UNIV OF POSTS & TELECOMM +1
Multi-peak miniaturized micro-strip equalizer with adjustable equalization quantity and monotonicity
PendingCN113992177AAccurate Compensation CorrectionImproved Gain FlatnessMultiple-port networksCoupling devicesSpurlineImpedance matching
The invention discloses a multi-peak miniaturized micro-strip equalizer with adjustable equalization quantity and monotonicity. The multi-peak miniaturized micro-strip equalizer comprises a microwave printed board, an input and output micro-strip line, an impedance matching transmission line, a high impedance line, a first low impedance line, a second low impedance line, a first resistor, a second resistor, an adjustable branch line and a gold wire for bonding, the multi-peak miniaturized micro-strip equalizer has the advantages that the purpose of adjusting the balance quantity is achieved, more reasonable compensation correction can be carried out according to the actually needed balance quantity, and microwave signals with better in-band flatness are obtained.
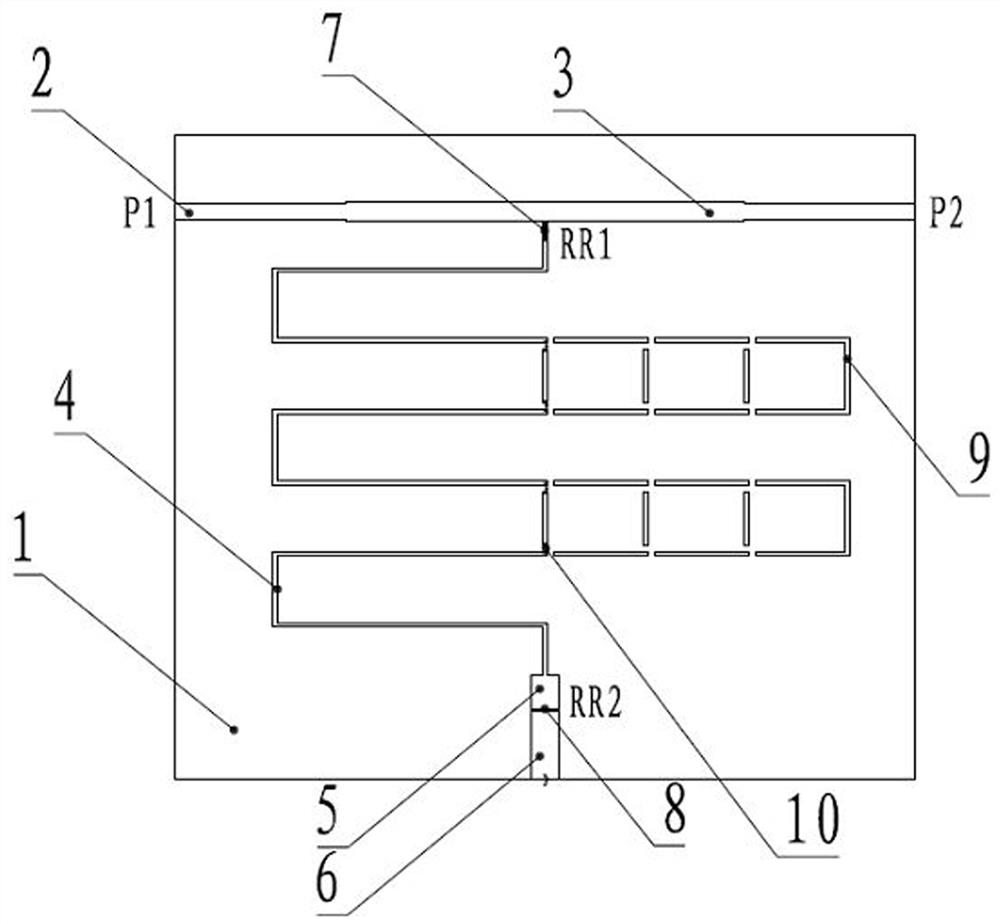
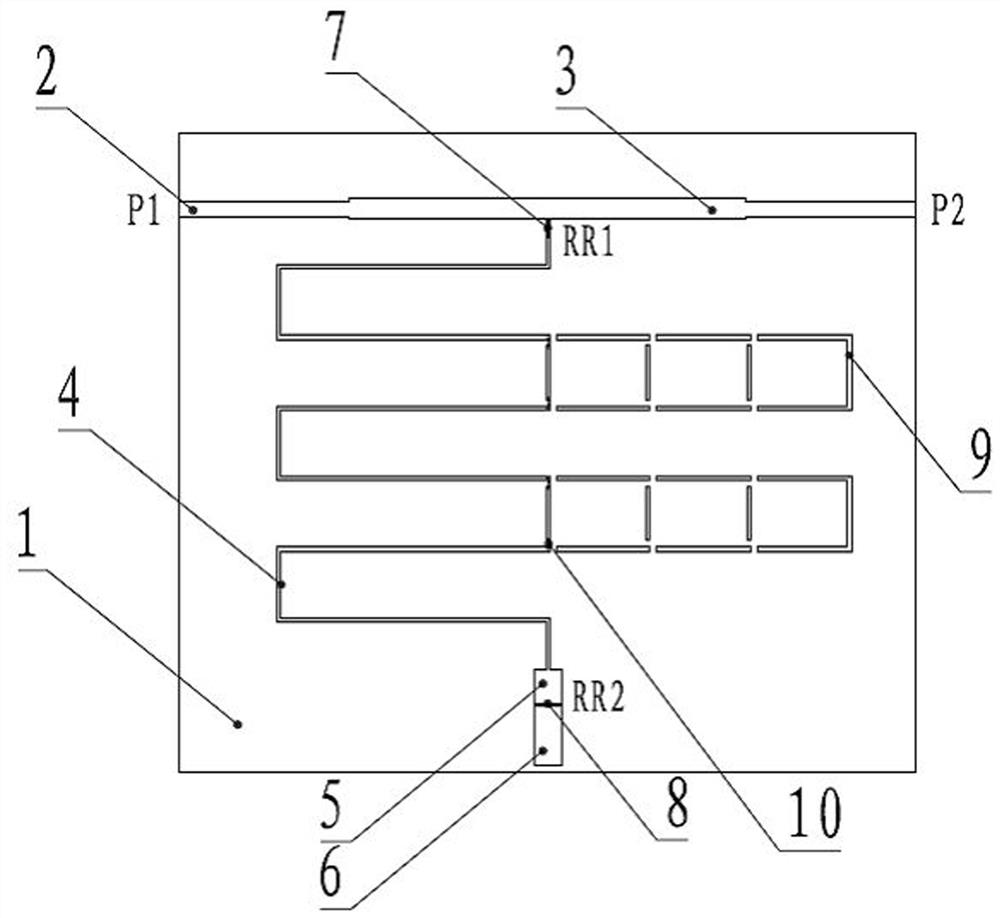
Owner:合利科技发展有限公司
A directional coupler and radio frequency front end module
The application relates to the field of radio frequency communication, and discloses a directional coupler. The directional coupler comprises a through main line, a first coupling branch line and a second coupling branch line. The through main line, the first coupling branch line and the second coupling branch line are arranged on a first substrate; wherein the first coupling branch line and the second coupling branch line are arranged on the two sides of the through main line respectively. The first coupling branch line and the second coupling branch line are connected through a coupling connection structure. The coupling connection structure is arranged on a second substrate. The area of the second substrate is smaller than that of the first substrate. The second substrate is welded on the first substrate.

Owner:GUANGZHOU HUIZHI MICROELECTRONICS
A compound microwave sensor and a method for measuring the dielectric constant of a measured object
ActiveCN107490727BAccurate measurementAccurate and reliable measurement resultsResistance/reactance/impedenceSpurlineTest object
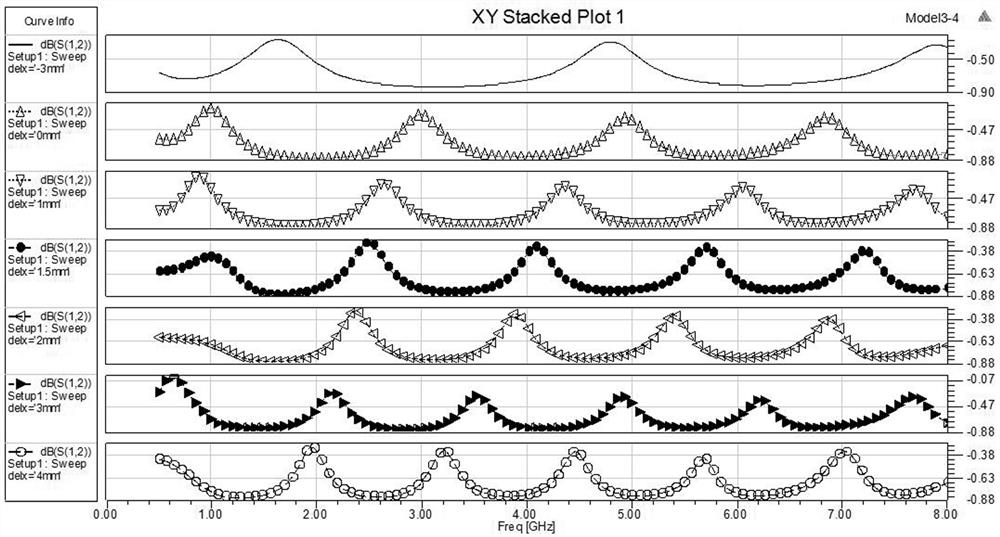
A combined microwave sensor comprises metal ground at the bottom layer, dielectric at the middle layer, an input port, an output port I, a branched line coupler, a power divider, an open resonant ring, a microstrip line I and a microstrip line II, wherein the input port, the output port I, the branched line coupler, the power divider, the open resonant ring, the microstrip line I and the microstrip line II are arranged in the top layer. The input port and the output port I are connected with a vector network analyzer. The output side of the branched line coupler is provided with an isolated port and the output port I. The input end of the power divider is connected with the input port. The output port II and the output port III are connected with an annular directional coupler through a microstrip line. The open resonant ring is arranged between the power divider, the branched line coupler and the two microstrip lines. The combined microwave sensor has advantages of effectively eliminating background noise, realizing testing for weak background signals, and ensuring large offset of the sensor resonant frequency through small disturbance of the tested object. Therefore the combined microwave sensor provided by the invention has higher sensitivity and higher accuracy in dielectric constant measurement and can be used in high-sensitivity testing with small dielectric constant change.
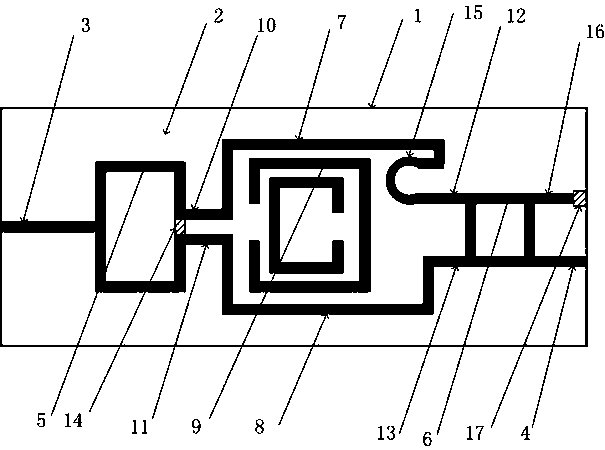
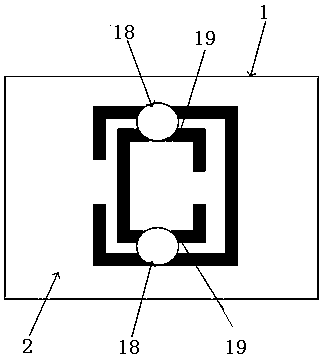
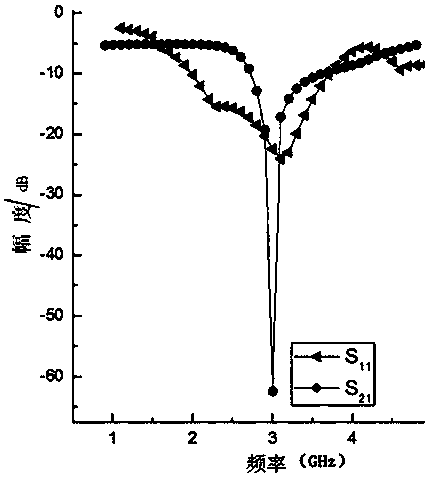
Owner:HENAN NORMAL UNIV
A terahertz broadband wide-angle pattern reconfigurable antenna
ActiveCN116154471BAntennas earthing switches associationHigh level techniquesReconfigurable antennaSpurline
The application provides a terahertz broadband wide-angle pattern reconfigurable antenna, and belongs to the field of radio frequency MEMS. The antenna comprises a tilted beam radiation unit, a tapered balun, a feed network, a MEMS switch network and a voltage bias line group; the feed network comprises one microstrip main feed line and four microstrip branch lines; three voltage bias line groups and one microstrip main feed line are distributed in a cross shape, the outer end of the microstrip main feed line is connected with the tapered balun, and the inner end of the microstrip main feed line is connected with the four microstrip branch lines through a two-stage bifurcation structure; the four tilted beam radiation units are connected with one microstrip branch line respectively; the MEMS switch network comprises three groups of switch structures, and the voltage bias line group at each bifurcation structure is used for controlling the opening and closing of the switch structure at the bifurcation structure, so as to realize the on-off of the corresponding microstrip line in the feed network. The application has the advantages of simple structure, convenient manufacturing, fast manufacturing and integration, and azimuth beam scanning.

Owner:THE 54TH RESEARCH INSTITUTE OF CHINA ELECTRONICS TECHNOLOGY GROUP CORPORATION