

Patents
Literature
17results about How to "Enhanced presence" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Excavator handle control system for remote operation
ActiveCN113220065AHigh sensitivityGood performanceControlling membersTotal factory controlDriver/operatorControl mode
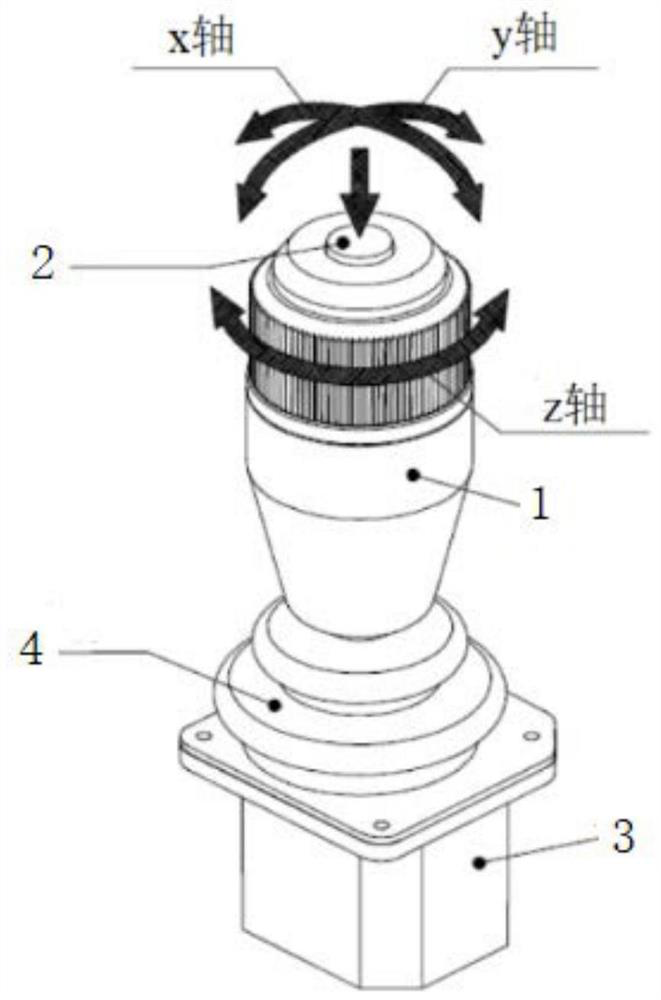
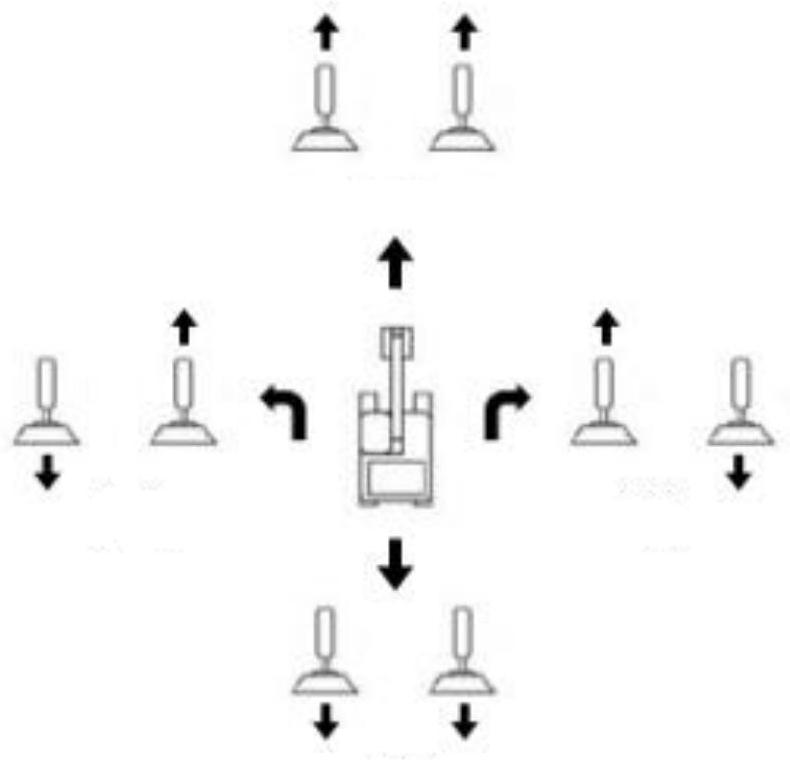
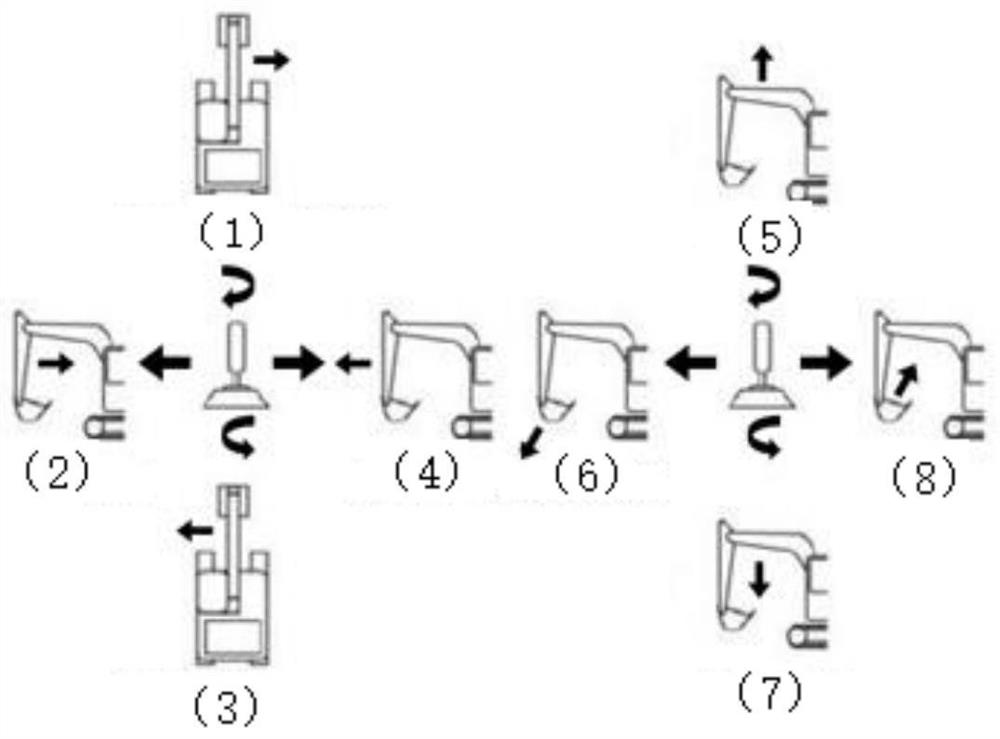
The embodiment of the invention provides an excavator handle control system for remote operation, a handle control method based on a Hall sensor is adopted, non-contact rocker data sensing is achieved, the influence of contact and movement abrasion on the service life of a handle is reduced, and the excavator handle control system has the advantages of being high in sensitivity and good in performance; the handle mechanism is more flexible to operate, and the service life of the handle is prolonged; a two-hand cooperative control mode is adopted, and two three-degree-of-freedom handles are used for simulating the driving environment of a real excavator, so that a good remote control effect is achieved, and the feeling of presence of an operator in the remote operation process is improved; the operation habits of a driver are fully considered, the walking and working of the excavator are respectively controlled through combination of different degrees of freedom of the left hand handle and the right hand handle, an operating lever of the real excavator is simulated in the aspects of structure, motion degree of freedom and working range, and the man-machine interaction environment of excavator driving is restored.
Owner:GUANGZHOU INST OF ADVANCED TECH CHINESE ACAD OF SCI
Media picture rendering optimization method and system based on artificial intelligence
ActiveCN119562120AEnhance visual habitsIn line with visual habitsDigital video signal modificationSelective content distributionComputer graphics (images)MediaFLO
The invention relates to the technical field of picture rendering, in particular to a media picture rendering optimization method and system based on artificial intelligence. The method comprises the following steps: acquiring a terminal video stream; performing RGB format conversion on the terminal video stream to generate an RGB type frame image set; pixel partitioning is carried out on the RGB type frame image set, and RGB pixel matrix blocks are generated; performing color space acceleration conversion on the RGB pixel matrix block to generate a YUV cache data matrix; the YUV storage data matrix is sent to a DSP internal processing unit for key frame selection, and YUV key video frame data and YUV non-key video frame data are obtained; and performing intra-frame coding on the YUV key video frame data so as to generate YUV key frame coded data. According to the method, the media picture rendering efficiency is improved by optimizing data processing, transmission and rendering and combining user visual focus analysis.

Owner:ZHUZHOU HUATONG TECH
Force feedback main manipulator suitable for puncture surgical robot
ActiveCN119523623Aincrease flexibilityReduce operational fatigue accumulationSurgical needlesSurgical manipulatorsPhysical medicine and rehabilitationSurgical robot
The invention discloses a force feedback main manipulator suitable for a puncture surgery robot, and belongs to the technical field of medical instruments, the force feedback main manipulator comprises a base, a position adjusting mechanism, a posture adjusting mechanism and a grip module, one end of the position adjusting mechanism is connected with the base, and the other end of the position adjusting mechanism is connected with the grip module; one end of the position adjusting mechanism is connected with the handle module, the other end of the position adjusting mechanism is connected with the posture adjusting mechanism, the handle module is arranged on the posture adjusting mechanism, and the position adjusting mechanism comprises a position compensation mechanism and a vertical position adjusting mechanism. According to the force feedback main manipulator suitable for the puncture surgery robot, complete decoupling of the position and the posture of the grip module is achieved, a real puncture surgery method is simulated, force feedback is provided for an operation doctor through the force feedback driving module, and the immediacy, intuition and flexibility of the doctor during operation are enhanced.

Owner:HARBIN UNIV OF SCI & TECH
Large-field-angle eyepiece optical system and head-mounted display device
The invention relates to a divisional application of which the application number is 202011626893.2. The invention relates to an eyepiece optical system with a large field angle and a head-mounted display device, and the system comprises a first lens group, a second lens group and a third lens group which are coaxially and sequentially arranged from a human eye observation side to a miniature image display side along an optical axis direction. The effective focal lengths of the first lens group, the second lens group and the third lens group are positive, negative and positive combinations; the first lens group comprises a first lens close to the human eye side and a second lens far away from the human eye side; the first lens group comprises at least two Fresnel optical surfaces; the first lens comprises at least one Fresnel optical surface; the second lens group includes a third lens adjacent to the first lens group; the third lens is a negative lens; the third lens group comprises a fourth lens, a fifth lens and a sixth lens which are adjacent to the second lens group and are sequentially arranged along the optical axis; the fourth lens and the sixth lens are positive lenses; the fifth lens is a negative lens; the system simultaneously realizes the indexes of large field angle, high image quality, low distortion, small field curvature, small size and the like.

Owner:SHENZHEN NED OPTICS CO LTD
End effector and human-machine collaborative robot arm end system
The present invention discloses an end effector and a human-machine collaborative robot arm end system, wherein the end effector comprises: a support frame, an operating assembly and a tool replacement assembly, wherein the operating assembly is arranged on the support frame, and the operating assembly has a handle for holding; the tool replacement assembly is arranged on the support frame, and the tool replacement assembly has a sleeve for clamping the tool, wherein the center axis of the handle is coaxial with the center axis of the sleeve. According to the end effector of an embodiment of the present invention, by providing a handle coaxial with the center axis of the sleeve, the operator's sense of presence in the process of controlling the robot arm can be enhanced, making the operation more intuitive and improving the operator's use experience.

Owner:TSINGHUA UNIVERSITY
A proxy presence robot control system and method
The application relates to the technical field of brain-computer interfaces, in particular to a proxy existence type robot control system and method. The system comprises a multi-modal brain and electromyography acquisition and analysis module, which is used for acquiring brain electrical signals and electromyography signals of a user, and performing data processing and intention recognition on the brain electrical signals and electromyography signals to generate a control intention; a control execution module, which is used for mapping the control intention into a control instruction executable by a robot to drive the robot to execute a corresponding action; an extended reality perception feedback module, which is used for acquiring environment perception data of a first visual angle of the robot and a first visual angle of the user to construct a two-way spatial mapping of a remote physical environment where the user and the robot are located, and provide immersive visual feedback to the user; and a communication interface module, which is used for realizing two-way data communication. The application can realize high-immersion, low-delay and high-reliability proxy existence type robot operation in a complex, dynamic or dangerous environment.

Owner:EAST CHINA UNIV OF SCI & TECH
Follow-up control method and system for intelligent glasses
PendingCN119521001Aincrease spaceEnhanced presenceImage enhancementInput/output for user-computer interactionSmartglassesCloud processing
The invention relates to the technical field of intelligent glasses, in particular to a follow-up control method and system for intelligent glasses, and the system comprises a user side glasses module, a cloud processing module, a remote follow-up module, a binocular camera disposed on a remote follow-up device, and an adjustment module. The remote follow-up module is used for copying the motion trail of the user side glasses module, the binocular cameras are used for collecting image information obtained when the remote follow-up module moves, and the adjusting module is used for adjusting the distance between the binocular cameras; according to the follow-up control method and system for the intelligent glasses, the image data collected by the binocular camera and the real-time feedback of the motion state of the intelligent glasses are combined, so that precise modeling of the surrounding environment and optimization of depth perception are achieved, and therefore the use experience of a user is improved.

Owner:东莞市三奕电子科技股份有限公司
Reality extended display device
Provided is a reality-extended display device that improves the presence of a display image. The present invention relates to a reality-extended display device capable of allowing a user to visually recognize a first image and a second image having different distances in a state in which a real environment is visually recognized, the reality-extended display device comprising: a display panel that emits polarized light for the first image and the second image; a plane-split polarized light conversion member disposed at a position at which the polarized light is incident; and an optical element and a concave half mirror disposed at a position at which the polarized light that has passed through the surface-divided polarized light conversion member is incident, the surface-divided polarized light conversion member having: a first transmissive portion that transmits the polarized light for the first image in a plan view, and a second transmissive portion that transmits the polarized light for the second image in a plan view; and a second transmissive section that transmits polarized light for a second image and generates a phase difference of [lambda] / 2 from the first transmissive section, the optical element causing a virtual image distance of a first image generated from the first polarized light transmitted through the first transmissive section to differ from a virtual image distance of a second image generated from the second polarized light transmitted through the second transmissive section.

Owner:SHARP DISPLAY TECHNOLOGY CORP
Large-field-angle eyepiece optical system and head-mounted display device
The invention relates to a divisional application of which the application number is 202011621711.2. The invention relates to an eyepiece optical system with a large field angle and a head-mounted display device, and the system comprises a first lens group, a second lens group and a third lens group which are coaxially and sequentially arranged from a human eye observation side to a miniature image display side along an optical axis direction. The effective focal lengths of the first lens group, the second lens group and the third lens group are positive, negative and positive combinations; the first lens group is composed of two optical lenses, namely a first lens close to the human eye side and a second lens away from the human eye side. The first lens group comprises at least two Fresnel optical surfaces; the first lens comprises at least one Fresnel optical surface; wherein the second lens group comprises third lenses which are adjacent to the first lens group and are sequentially arranged along the optical axis; the third lens group comprises a fourth lens and a fifth lens which are adjacent to the second lens group and are sequentially arranged along the optical axis; the system can realize the indexes of large field angle, high image quality, low distortion, small field curvature, small size and the like.

Owner:SHENZHEN NED OPTICS CO LTD
Apparatus for displaying virtual object and display method thereof
PendingCN119156661AEnhanced presenceCathode-ray tube indicators3D modellingInformation processingComputer graphics (images)
The invention provides an apparatus for displaying a virtual object and a display method thereof, which can improve the presence of a user even under the condition that the virtual object cannot be seen. To this end, the method for displaying a virtual object comprises: a map information processing step in which a first map element corresponding to position information and a second map element corresponding to a predetermined pattern are extracted from map data; a virtual object processing step of arranging a virtual object on a real object of a real space corresponding to the first map element; an auxiliary information processing step of generating a map element object corresponding to the second map element; a display processing step in which, among the virtual object and the map element object, a drawing method is made different for a portion located in front of the real object and a portion located behind the real object; and a display step: displaying the virtual object and the map element object processed by the display processing step in a real space in an overlapping manner.

Owner:MAXELL LTD
Robotic teleoperation system and method based on visual positioning and virtual reality technology
The application discloses a kind of robot teleoperation systems based on visual positioning and virtual reality technology, including robot located in remote space, depth camera and scene reconstruction system, robot includes robot control system and robot execution system;Virtual reality device and virtual engine located in local operating space;Scene reconstruction system generates remote robot work scene;Virtual engine is connected with virtual reality head-mounted display and handheld controller, it generates virtual robot according to actual robot size, and generates initial virtual robot work space based on the three-dimensional point cloud information of remote robot work scene and the initial pose data of robot work object;It changes virtual robot pose and virtual robot work space according to the control signal of handheld controller.The application realizes the three-dimensional reconstruction of remote environment based on point cloud and 6D pose estimation algorithm, and feeds back to operator by virtual reality device, avoids the delay of point cloud continuous transmission.


Owner:TIANJIN UNIV
Conference live broadcast method, conference live broadcast device and electronic equipment
InactiveCN119135831AImprove realismImprove interactivityTelevision conference systemsTwo-way working systemsSound sourcesData stream
The invention discloses a conference live broadcast method and device and electronic equipment, and relates to the field of data processing. The method comprises the following steps: acquiring video data; splicing the video data to obtain panoramic video data; acquiring audio data of a conference room; performing sound source positioning on the audio data to obtain spatial position coordinates of each spokesman; generating an audio data stream; performing voice recognition on the audio data stream to obtain a voice text of a spokesman; translating the voice text into a target language to obtain a translated text, and generating a subtitle data stream; performing time synchronization on the panoramic video data stream, the audio data stream and the subtitle data stream to obtain a target audio and video data stream; and sending the target audio and video data stream to VR glasses, so that the VR glasses can perform live broadcast on conference content of the conference room. According to the technical scheme, the recognized voice text is translated into the translated text of the target language, it is ensured that participants of different languages can understand the conference content, and the experience feeling of the conference participants is improved.

Owner:SHANGHAI XIANGZHE INTELLIGENT TECHNOLOGY CO LTD
Large-field-angle eyepiece optical system and head-mounted display device
The invention relates to a divisional application of which the application number is 202011626965.3. The invention also relates to a preparation method of the invention. The invention relates to an eyepiece optical system with a large field angle and a head-mounted display device, and the system comprises a first lens group, a second lens group and a third lens group which are coaxially and sequentially arranged from a human eye observation side to a miniature image display side along an optical axis direction. The effective focal lengths of the first lens group, the second lens group and the third lens group are positive, negative and positive combinations; the first lens group is composed of two optical lenses, namely a first lens close to the human eye side and a second lens away from the human eye side. The first lens group comprises at least two Fresnel optical surfaces; the second lens group is composed of two optical lenses. Wherein the second lens group comprises a third lens and a fourth lens which are adjacent to the first lens group and are sequentially arranged along the optical axis; the third lens and the fourth lens are both negative lenses; the third lens group is composed of two optical lenses. The system has the advantages of large field angle, high image quality, low distortion, small field curvature, small size and the like.

Owner:SHENZHEN NED OPTICS CO LTD
Video playing method, device and equipment and readable storage medium
PendingCN119520873AImprove playback qualityEnhanced presenceSelective content distributionStereophonic systemsSound imageEngineering
The embodiment of the invention discloses a video playing method, apparatus and device, and a readable storage medium. An electronic device determines a spatial position of a target role for sounding in a video frame relative to a reference point. Afterwards, a dialogue signal corresponding to the video is determined, after the dialogue signal is sent by the target role, the dialogue signal is rendered according to the spatial position of the target role relative to the reference point so as to obtain multiple paths of voice signals, and the path number of the multiple paths of voice signals is the same as the first number of loudspeakers of the electronic equipment. And finally, the electronic equipment synchronously plays the video frames and the multiple paths of voice signals. By adopting the scheme, the electronic equipment renders the dialogue signal according to the spatial position of the target role in the video frame, so that the spatial position of the target role is consistent with the sound image position of the dialogue signal, and the presence of a user is enhanced while the video playing quality is improved.

Owner:GUANGZHOU SHIYUAN ELECTRONICS CO LTD +1
An underwater drilling device for plugging cracks in tunnel concrete lining and its operation method
The invention discloses an underwater drilling device for plugging cracks in concrete lining of a tunnel and an operating method thereof, comprising an underwater robot and an underwater electric drill used in conjunction therewith, wherein the outer shell and a thin-walled rear cover of the underwater electric drill are both hexagonal, the outer shell edge is provided with a groove and a snap-fitting strip corresponding to the groove of the other outer shell, the two outer shells and the thin-walled rear cover are combined to wrap a motor and a reducer, and a sealing material is packaged in the groove gap; 12 clamping protrusions corresponding to the robot's mechanical arm clamping claws are provided on the surface of the outer shell; a sealing rubber layer is provided on the surface of the thin-walled rear cover; a circular front sleeve is provided at the front end of the outer shell, and a skeleton oil seal is provided between the front end of the outer shell and the front sleeve, and the skeleton oil seal has at least two layers; the drill bit is a special drill bit for concrete, the device and the operating method meet the drilling operation requirements for plugging cracks and the like in an underwater environment, avoid workers from going into water for operation, improve work efficiency and safety, and reduce the cost of underwater drilling.

Owner:SOUTHEAST UNIV
Environmental noise generation method and device, equipment and storage medium
PendingCN119517075Aincrease interest in readingEnhanced presenceSemantic analysisSpeech analysisNoise generationEnvironmental noise
The invention relates to the field of artificial intelligence, and discloses an environment noise generation method and device, equipment and a storage medium, and the environment noise generation method comprises the steps: obtaining the text description information of to-be-generated environment noise; according to the text description information, environment noise matched with the text description information and noise attributes of the environment noise are determined, and the noise attributes at least comprise sound intensity proportion probabilities corresponding to the environment noise and azimuth information corresponding to the environment noise; obtaining timbre materials matched with each environment noise from a timbre material database; and synthesizing the audio material into target environment noise by using a preset sound source simulation function according to the sound intensity proportion probability and the azimuth information of the environment noise. According to the environment noise generation method provided by the invention, the environment noise is generated based on the text description information, so that the output environment noise is adaptive to the text description information, and a user has stronger immediacy and immersion after hearing the text description information.

Owner:PING AN TECH (SHENZHEN) CO LTD
A video frame processing method, device and storage medium
PendingCN122741654AIncrease blur intensityAvoid loss of sense of space
This application discloses a video frame processing method, apparatus, and storage medium, belonging to the field of video processing technology. The method may include: acquiring a first video frame and its depth information; determining a target object region in the first video frame; determining the content attributes of each sub-region in the region other than the target object region in the first video frame; determining a depth reference plane based on the depth information, wherein the spatial position of the depth reference plane corresponds to the depth position of the target object region in the first video frame; performing differential blurring on the region other than the target object region in the first video frame to obtain a processed first video frame; and outputting the processed first video frame. In the differential blurring, sub-regions in the region that have the same depth distance to the depth reference plane but different content attributes are subjected to different degrees of blurring. In the differential blurring, the degree of blurring of each sub-region is jointly determined by the depth distance of the sub-region to the depth reference plane and the content attributes of the sub-region.

Owner:YEALINK (XIAMEN) NETWORK TECHNOLOGY CO LTD