

Patents
Literature
52results about How to "Reduce flight risk" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Hypersonic speed aircraft control method capable of suppressing constant deviation influence of sideslip angle signal
ActiveCN103587681ASteady state error zeroHigh control precisionActuated automaticallyAdaptive controlEngineeringOmega
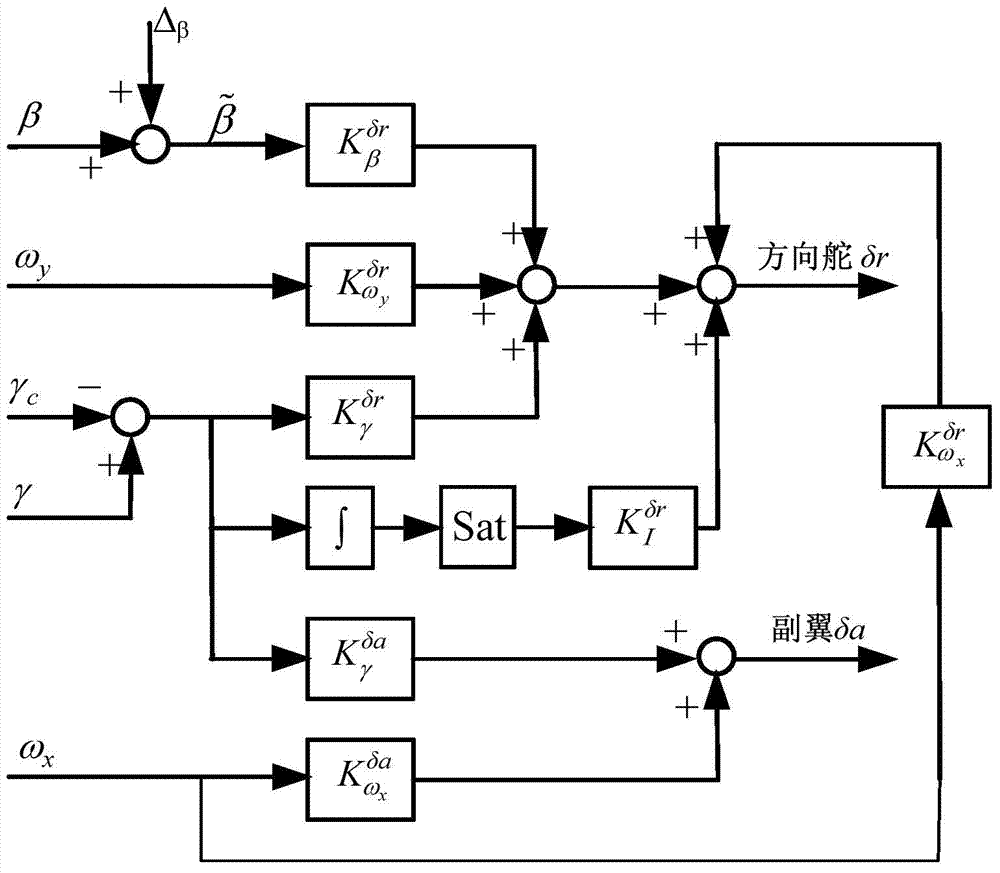
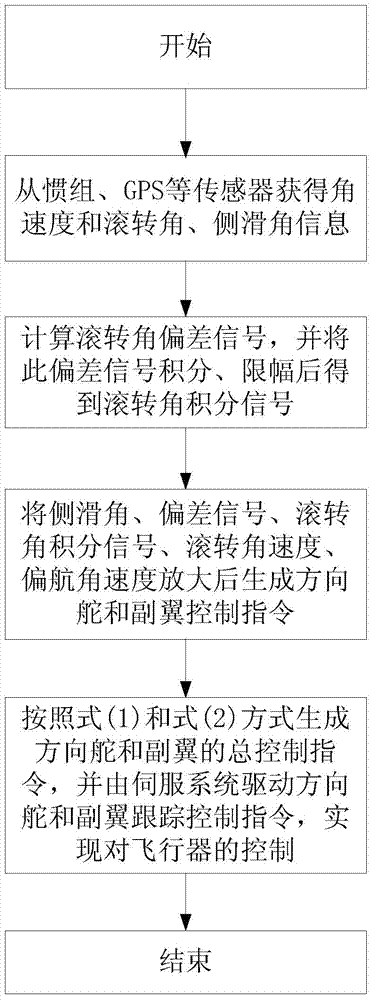
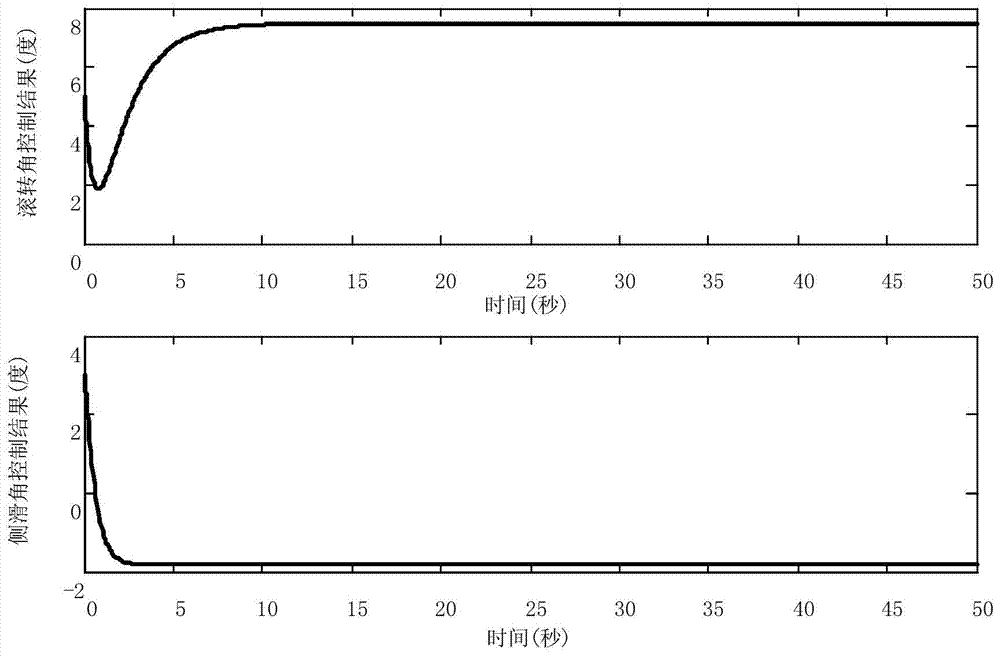
The invention discloses a hypersonic speed aircraft control method capable of suppressing the constant deviation influence of a sideslip angle signal. The method comprises the following steps: (1) measuring the yaw angle speed omega y and the roll angle speed omega x of an aircraft in real time by utilizing an inertial measurement unit, and acquiring a roll angle gamma and a sideslip angle by utilizing the inertial measurement unit and a sensor; (2) calculating a deviation signal of the gamma and a roll angle instruction gamma c, integrating a deviation signal Delta gamma, and performing the amplitude limiting on the deviation signal, so as to obtain a roll angle integrated signal; (3) amplifying the roll angle integrated signal and the omega y, generating a control instruction, and feeding the control instruction back to a rudder of the aircraft; amplifying the omega x, generating a control instruction I and feeding the control instruction I back to an aileron of the aircraft; amplifying the Delta gamma, generating a control instruction II and feeding the control instruction II back to the rudder / aileron of the aircraft; (4) adding all the control instructions which are fed back to the rudder to serve as a general control instruction of the rudder, and controlling the rudder to track the general control instruction through a servo system on the aircraft; adding all the control instructions I fed back to the aileron to serve as a general control instruction I of the aileron, and controlling the aileron to track the general control instruction through the servo system on the aircraft.
Owner:CHINA ACAD OF LAUNCH VEHICLE TECH
Simulation test method and simulation test system for unmanned aerial vehicle (UAV) system
InactiveCN102109418AReduce flight riskAvoid flying risksStructural/machines measurementBackground informationReal time display
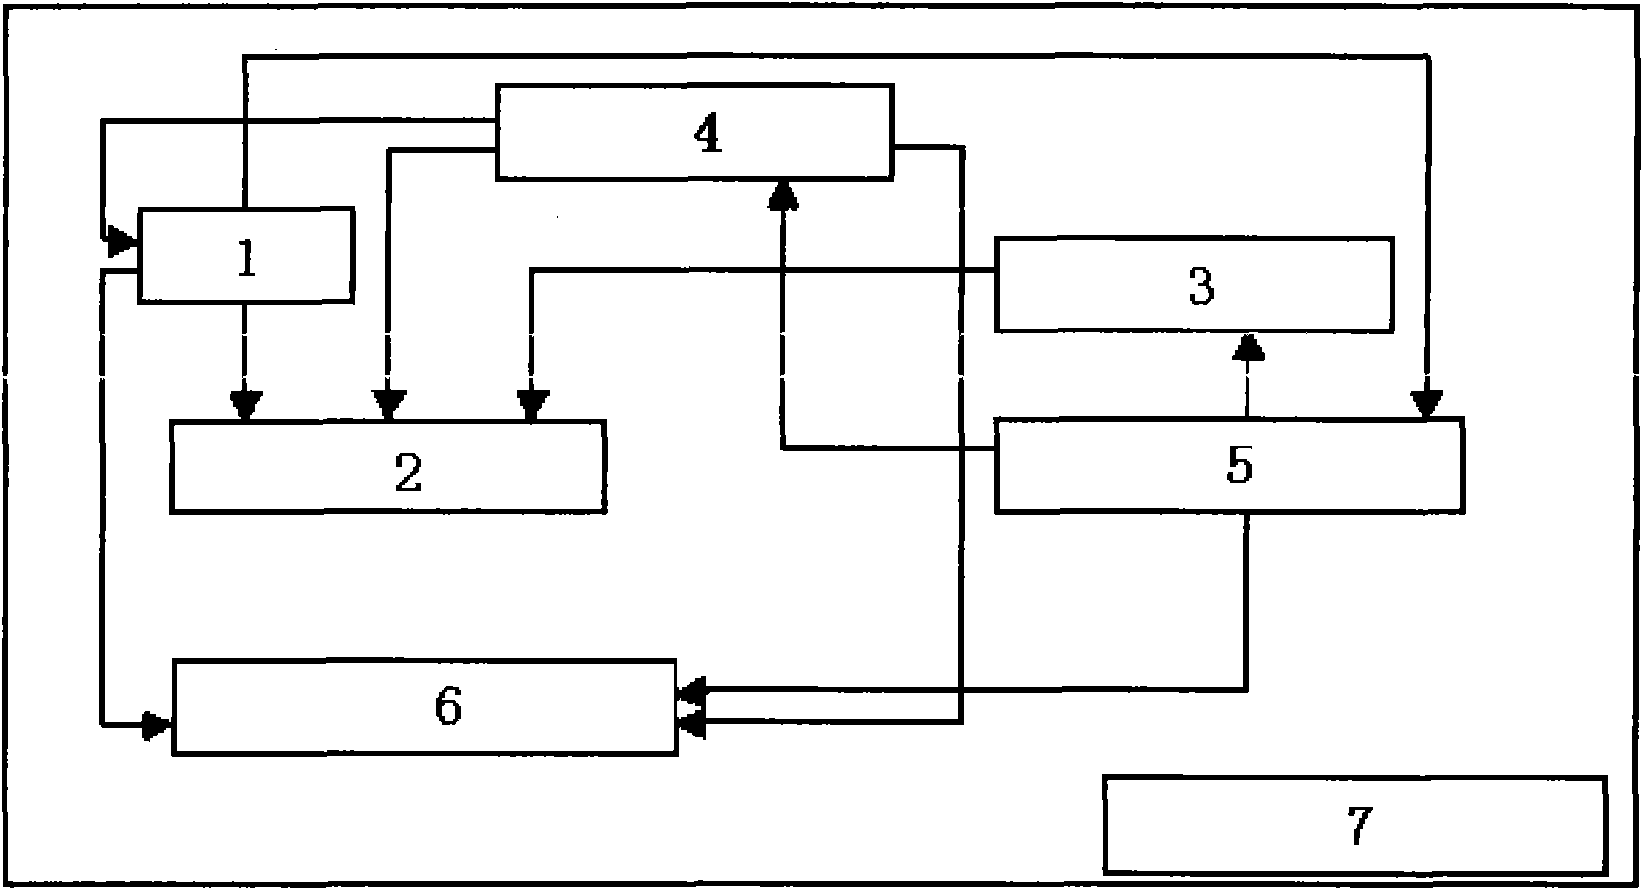
The invention discloses a simulation test method and a simulation test system for an unmanned aerial vehicle (UAV) system. The method comprises the following steps of: arranging the UAV system on a multi-latitude motion platform system, and providing the multidimensional motion of the UAV system by using the multi-latitude motion platform system; providing signal data of simulated motion for the UAV system by using a signal source simulation system; providing a control logic process of motion simulation, platform motion amount closed loop measurement and the corresponding measurement of the UAV system by using a control and measurement system; and providing a drive source required by the motion of the multi-latitude motion platform system by using a motion servo system, and providing a parameter record, real-time display and superposed background information by using a simulation parameter recording and displaying system. By the method and the system, the UAV system can be subjected to dynamic test check and simulation on the ground, and actual flight is replaced, so that actual flight risk is obviously reduced, a test verification period is shortened, and cost is saved.
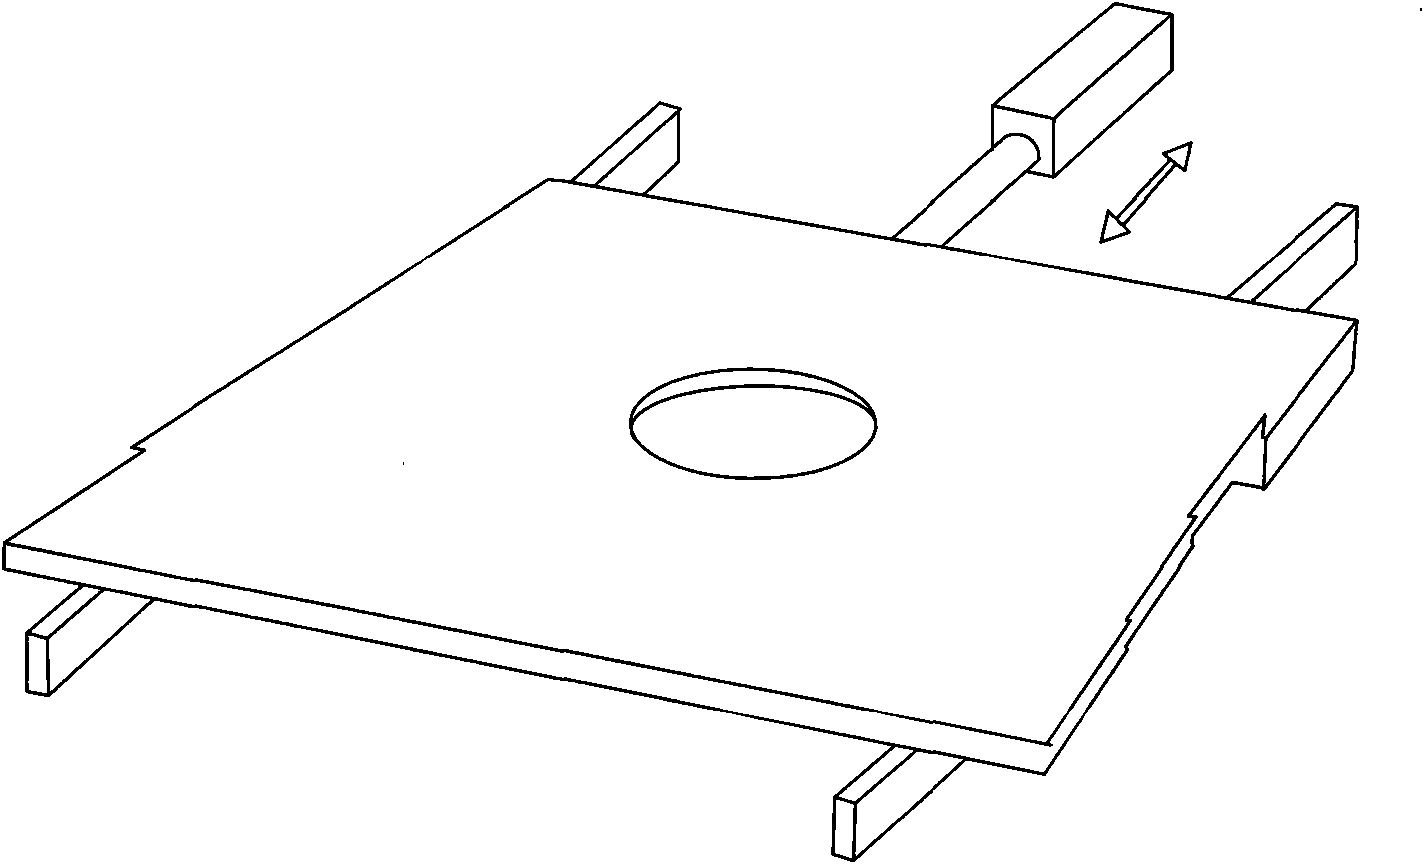
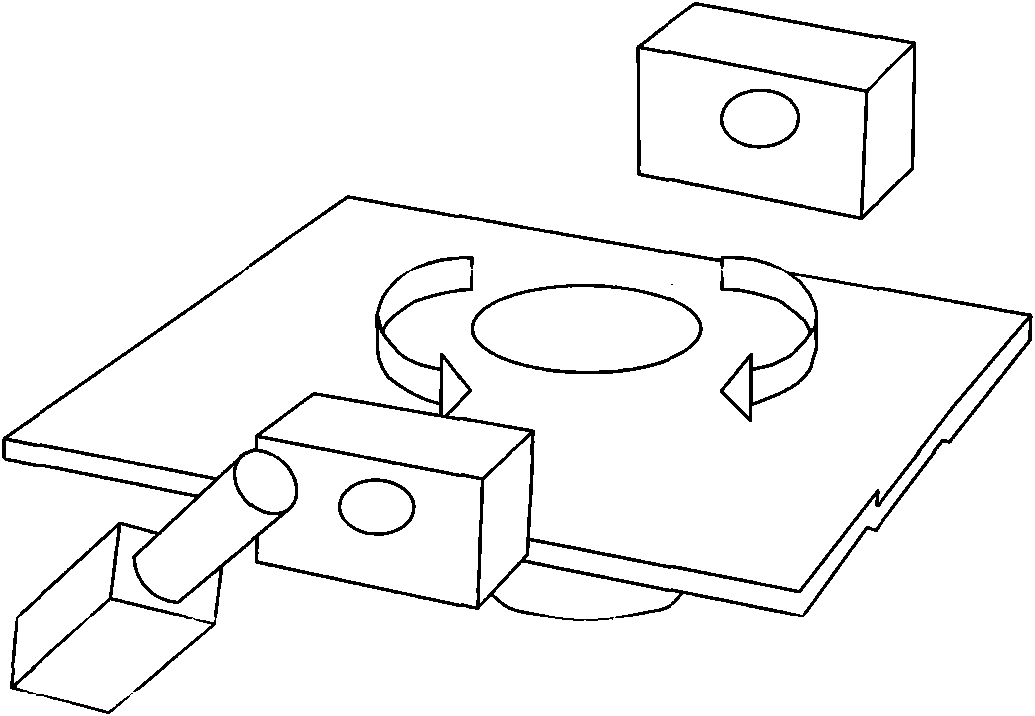
Owner:贵州贵航无人机有限责任公司
Inner field radiation type complex electromagnetic environment building method and simulation system
ActiveCN105511296AImprove confidentialityShorten the test cycleSimulator controlSurvivabilityAnechoic chamber
The invention discloses an inner field radiation type complex electromagnetic environment building method, and the method comprises the steps: taking a reasonably-configured anechoic chamber as a testing platform, and constructing complex electromagnetic environment signals through various types of signal simulators, wherein the parameters of signal simulators can set flexibly; irradiating target, interference, clutter and background environment electromagnetic signals to tested equipment through a radiation unit arranged in the anechoic chamber. The invention also discloses a simulation system, and the simulation system comprises the anechoic chamber, a control chamber, a signal chamber, a rotating table, a suspension mechanism, a background environment simulator, a signal simulator, a radiation array, a feed system, a moving vehicle, a rail, a discrete receiving and transmitting unit, a bandwidth receiver, a computer, and a control system. The method provides a high-efficiency, reliable, repeatable and high-cost-performance technological means for the complex electromagnetic environment effect testing of an electronic system. The method has great application values in shortening the development period of the electronic system, reducing the testing consumption and improving the battlefield survival capability of equipment.


Owner:NANJING CHANGFENG AEROSPACE ELECTRONICS SCI & TECH
Automatic power-off method and device for mobile terminal
The invention provides an automatic power-off method and device for a mobile terminal. The method comprises the step of receiving interaction information which is the information sent to the mobile terminal by an airport, and the step of executing automatic powering off according to the interaction information. According to the method, the mobile terminal can be automatically powered off when departure time is up after boarding, the mobile terminal is forced to be powered off during the flying process of an airplane, the flying safety is improved, and the flying risk is reduced.


Owner:SAMSUNG GUANGZHOU MOBILE R&D CENT +1
Vector propelling device for two-shaft linkage propeller for airship
InactiveCN105620709AReduce weightSolve installation problemsRigid airshipsElectric machineryPropeller
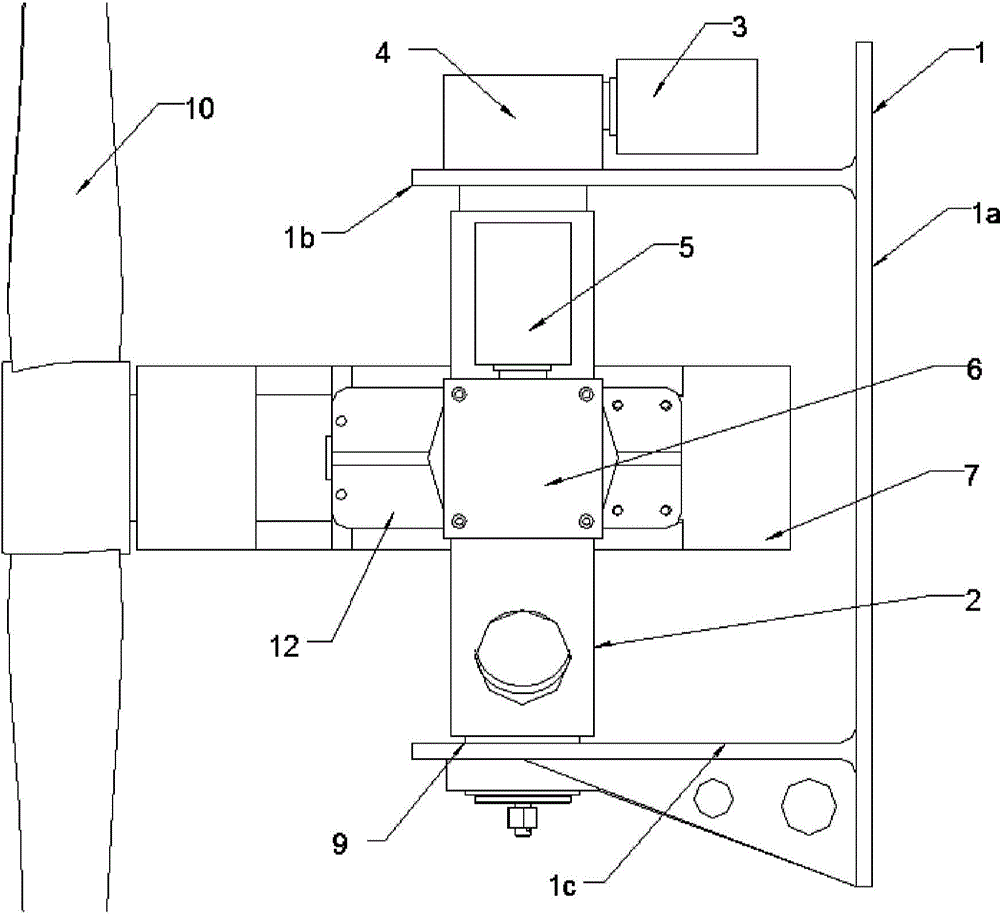
The invention provides a vector propelling device for a two-shaft linkage propeller for an airship. The vector propelling device comprises an outer supporting frame, a yaw mechanism part and a pitching mechanism part. The outer supporting frame and a tail cabin or a hard tail supporting structure of the airship are connected depending on locating screw holes distributed in a side board of the outer supporting frame, so that the outer supporting frame is arranged at the tail portion of the airship. The yaw mechanism part and the outer supporting frame are fixedly connected. The pitching mechanism part is embedded in the yaw mechanism part to be fixedly connected with an inner rotary frame of the yaw mechanism part. A propeller of the pitching mechanism part rotates at a high speed synchronously along with a propelling motor, thrust is generated, the yaw mechanism part takes charge of the orientation yaw of the propeller, the pitching mechanism part takes charge of the posture adjustment of the propeller, and auxiliary propelling, yaw and pitching of the airship can be achieved synchronously. Two-shaft linkage is adopted in the vector propelling device, closed-loop control is conducted, the rotation angle is accurately controlled, the weight is reduced, an installation problem is solved, the flight risks and energy consumption are reduced, and climbing, flat flight, fixed-point flight and landing of the airship are achieved successfully.
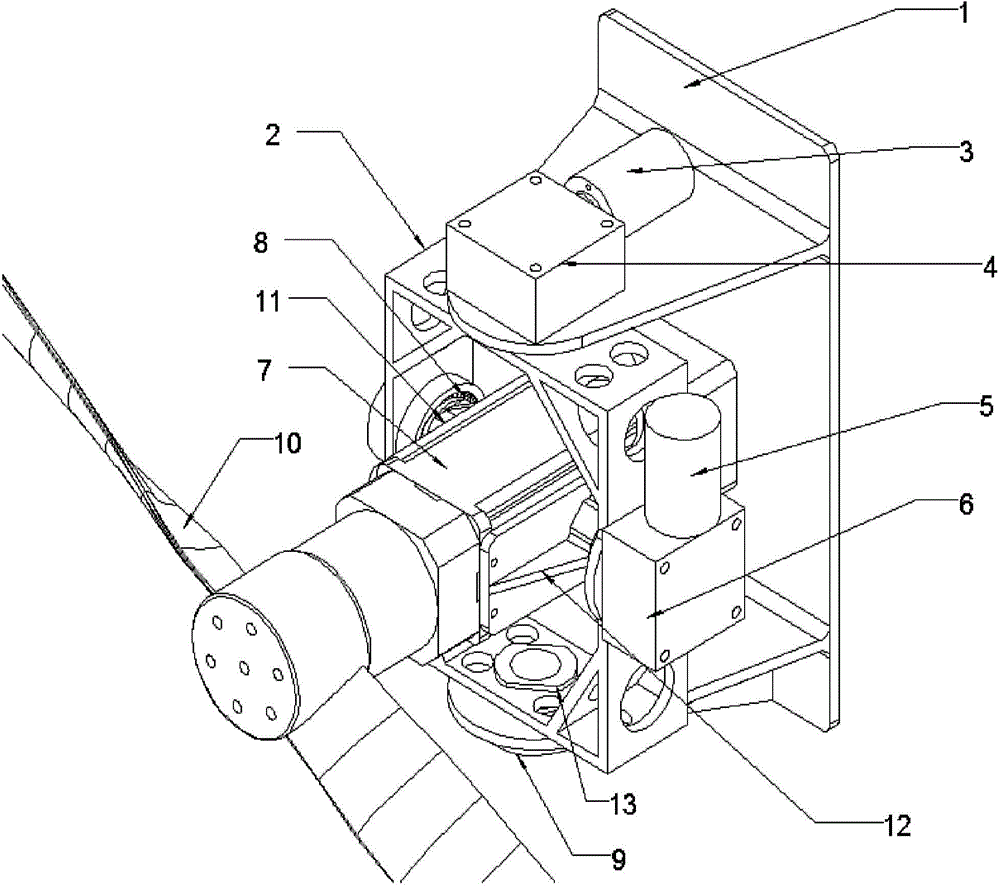
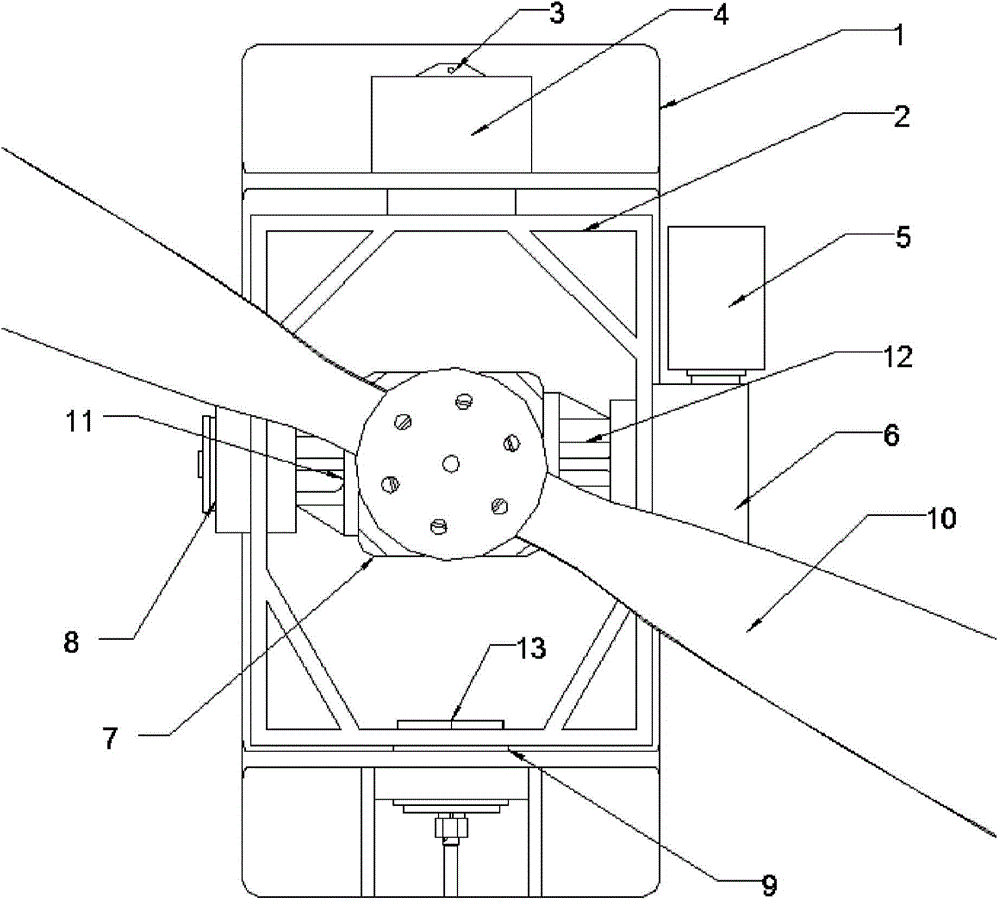
Owner:ACAD OF OPTO ELECTRONICS CHINESE ACAD OF SCI
Rotary acceleration type magnetic suspension electromagnetic propulsion test system and method
ActiveCN112504615ASolve scale constraintsSolve the test incoming gas compositionAerodynamic testingFlight vehicleControl system
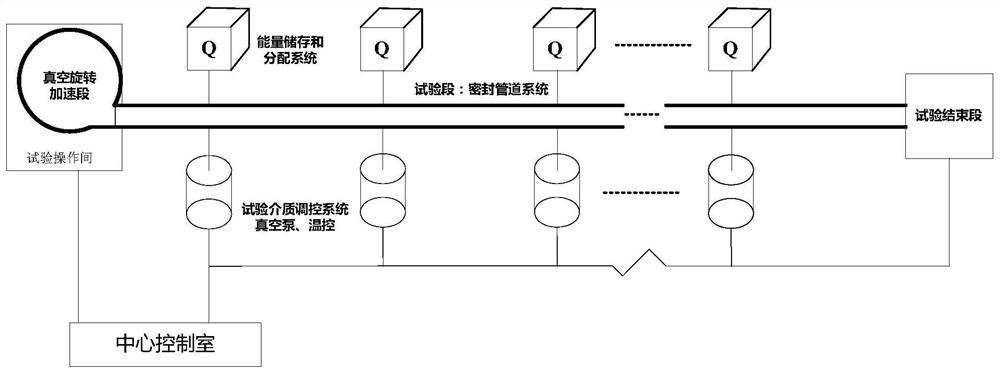
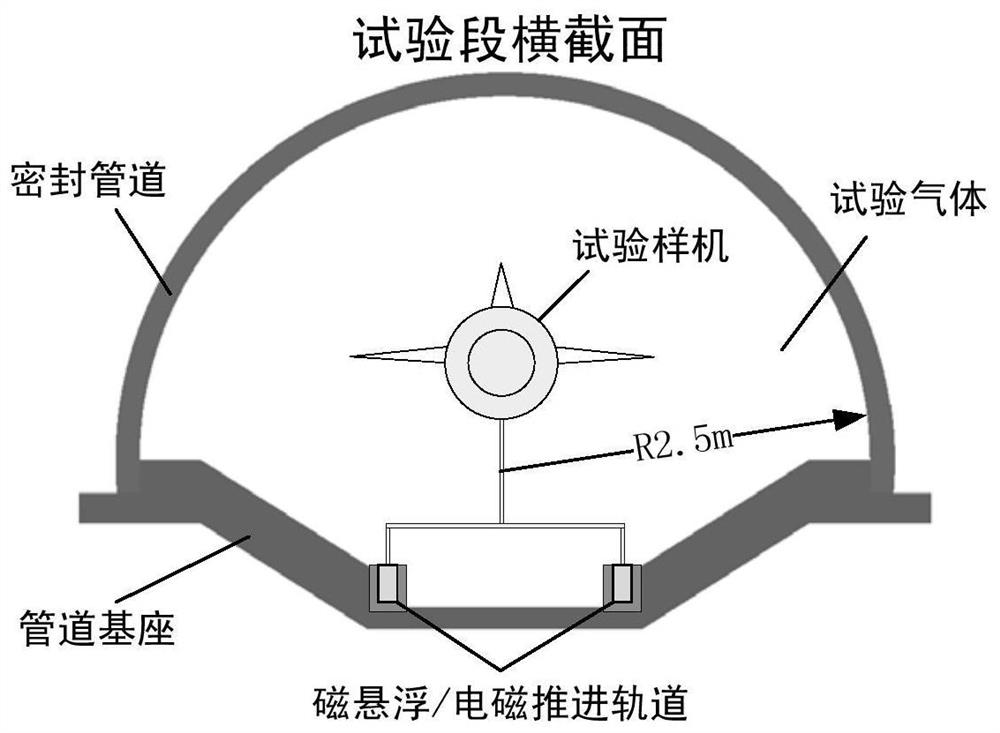
A rotary acceleration type magnetic suspension electromagnetic propulsion test system comprises a vacuum rotary acceleration section, a test section, a magnetic suspension electric propulsion system,an energy storage and distribution system, a test gas medium regulation and control system and a test data measurement system, the test model obtains an initial speed through rotation acceleration andenters a test section, a magnetic levitation electric propulsion system is arranged in the test section, and the test model is subjected to speed control through the magnetic levitation electric propulsion system to simulate a flight trajectory; the energy storage and distribution system and the test gas medium regulation and control system are both arranged on the outer side of the test section,the energy storage and distribution system is used for supplying power to the magnetic levitation electric propulsion system and the test gas medium regulation and control system, and the test gas medium regulation and control system is used for regulating gas pressure and temperature in the closed test section; the test data measurement system is used for collecting test model motion data. The problems that an original test equipment test model is limited in size, test gas is polluted, and the sky-ground difference limits the aircraft technology are solved.
Owner:CHINA ACAD OF LAUNCH VEHICLE TECH
Sparse space wind vector field abnormity early warning method based on multi-source heterogeneous spatio-temporal data
ActiveCN119311933AHigh precisionImprove reliabilityDigital data information retrievalSpecial data processing applicationsAlgorithmWind field
The invention provides a sparse space wind vector field abnormity early warning method based on multi-source heterogeneous spatio-temporal data. Comprising the following steps: S1, obtaining multi-source heterogeneous wind vector data and carrying out space-time standardization; s2, constructing a multi-scale geographic spatio-temporal weighted autoregression model and updating the weight; s3, decomposing a vector field and constructing a regional early warning pilot feature set; s4, boundary flux calculation and PINN-GPR fitting of a sparse space connected domain are carried out; s5, four-dimensional spatio-temporal data variational assimilation and sparse space boundary flux updating are carried out; and S6, abnormal wind field early warning based on regional early warning pilot feature matching. According to the method, the abnormal early warning of the sparse space wind vector field and the adaptive updating of the early warning library can be realized.

Owner:CIVIL AVIATION UNIV OF CHINA
Path planning method, device and equipment based on multi-target unmanned aerial vehicle, and storage medium
PendingCN119104052Asave human effortsave moneyOptical rangefindersNavigational calculation instrumentsSimulationUncrewed vehicle
The invention discloses a path planning method, device and equipment based on a multi-target unmanned aerial vehicle, and a storage medium, and the method comprises the steps: collecting the geographic information data of an inspection region, building a planning path database according to the collected data, and carrying out the preprocessing and optimization of the data; solving an unmanned aerial vehicle path planning model based on a particle swarm algorithm according to maneuvering characteristics, safety constraint conditions and routing inspection target priorities of unmanned aerial vehicle flight; unconventional obstacles are detected in real time based on an unmanned aerial vehicle visual system, and local safety adjustment of a path is achieved; and the updated path is synchronously sent to a remote client, and path evaluation and manual intervention are carried out. According to the method, the flight duration, the path smoothness and the path effectiveness are comprehensively considered, the method can adapt to complex environments and inspection requirements, the particle swarm optimization and the binocular distance measurement technology are comprehensively applied, the intelligence and the real-time performance of path planning are improved, the flight risk is reduced, and the safe work of the inspection requirements of the unmanned aerial vehicle is guaranteed.

Owner:STATE GRID JIANGSU ELECTRIC POWER CO XUZHOU POWER SUPPLY CO +1
Optimal path planning method based on three-dimensional low-altitude visual flight
ActiveCN112859930AReduce flight riskRealize multi-source data fusionPosition/course control in three dimensionsFlight vehicleLow altitude
An optimal path planning method based on three-dimensional low-altitude visual flight comprises the steps of constructing a three-dimensional measurable model, establishing a spatial database, constructing a flight image primitive network, calculating a flight area, planning a flight path and the like. According to the method, the impedance value of the gridding primitive network can be obtained based on the full-space database of the three-dimensional measurable model and containing accurate gridding geographic entity data, the flight picture primitive network corresponding to the full-space database is constructed, automatic flight of aircrafts such as unmanned aerial vehicles can be achieved, and a driver does not need to visually correct a flight route through landmarks.


Owner:泰瑞数创科技(北京)股份有限公司
Air-ground cooperative wetland air patrol method and device and electronic equipment
PendingCN119597002Aeffective monitoringeffective protectionVehicle position/course/altitude controlPosition/direction controlFly controlSimulation
The invention provides an air-ground cooperative wetland air patrol method and device and electronic equipment, and the method comprises the steps: making a patrol flight plan based on an operation region and a flight limiting region defined by an operation control management center; daily first flight confirmation is carried out, the unmanned aerial vehicle is controlled to take off under the condition that the flight control right is obtained, and automatic patrol is carried out according to the patrol flight plan. In the automatic patrol process of the unmanned aerial vehicle, image video data are collected in real time, the operation condition is monitored, and the real-time equipment state and alarm information of the unmanned aerial vehicle are obtained. Analyzing according to the image video data to obtain an inspection result, and generating an alarm signal when an abnormal condition exists in the inspection result. And judging whether the unmanned aerial vehicle has a fault based on the real-time state of the equipment and the alarm information, and controlling the unmanned aerial vehicle according to a preset fault handling strategy when the unmanned aerial vehicle has the fault. According to the method, an air-ground cooperation technology and an intelligent technology are combined, the wetland inspection efficiency is effectively improved, and intelligent management of the wetland protection area is realized.

Owner:JIAOTONG AVIATION TECHNOLOGY (SHENZHEN) CO LTD
Course reversal method and device of unmanned aerial vehicle
ActiveCN109991995AReduce riskNearbyPosition/course control in three dimensionsUncrewed vehicleComputer science
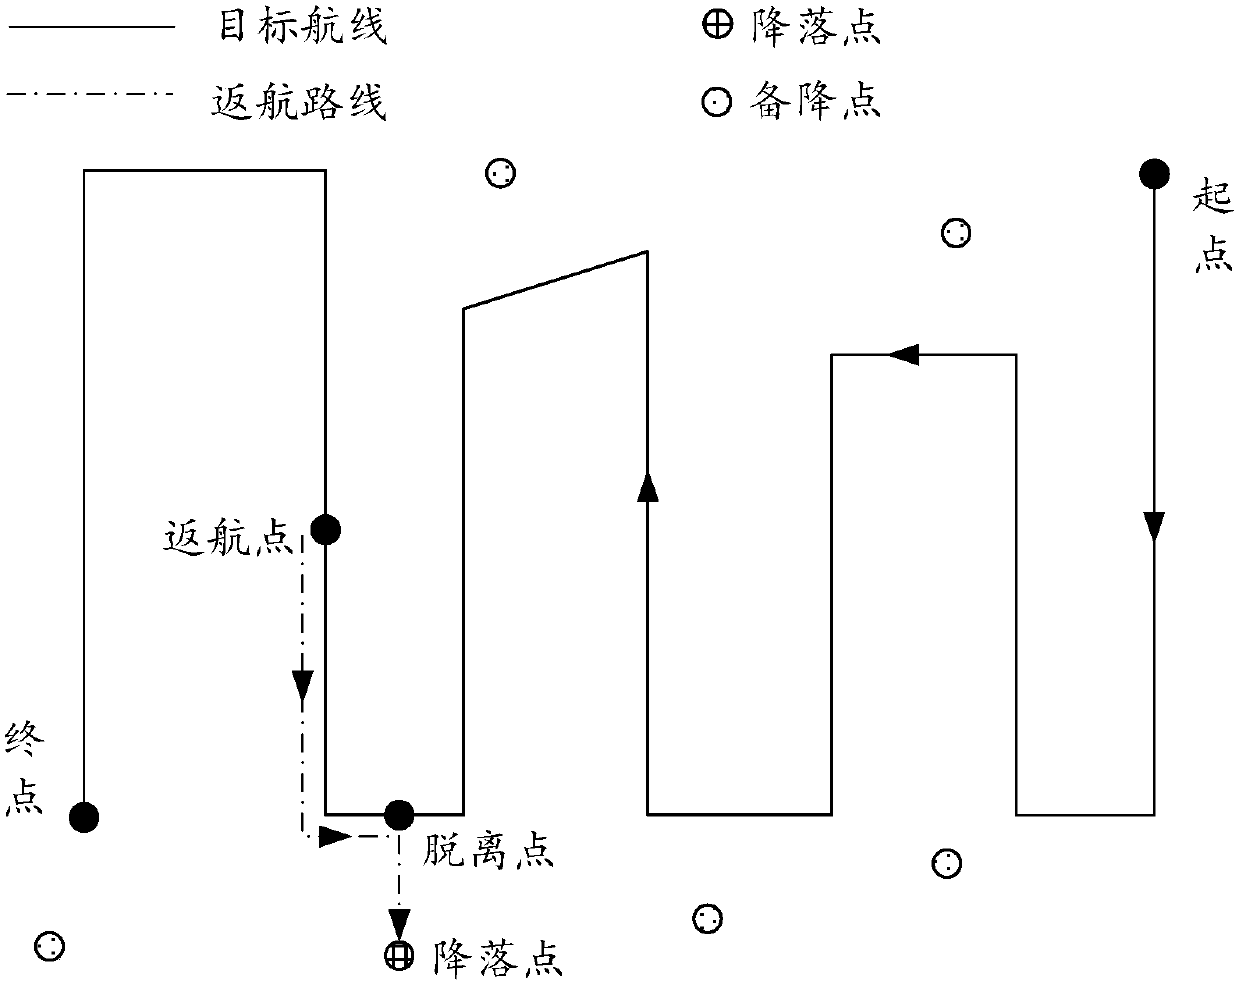
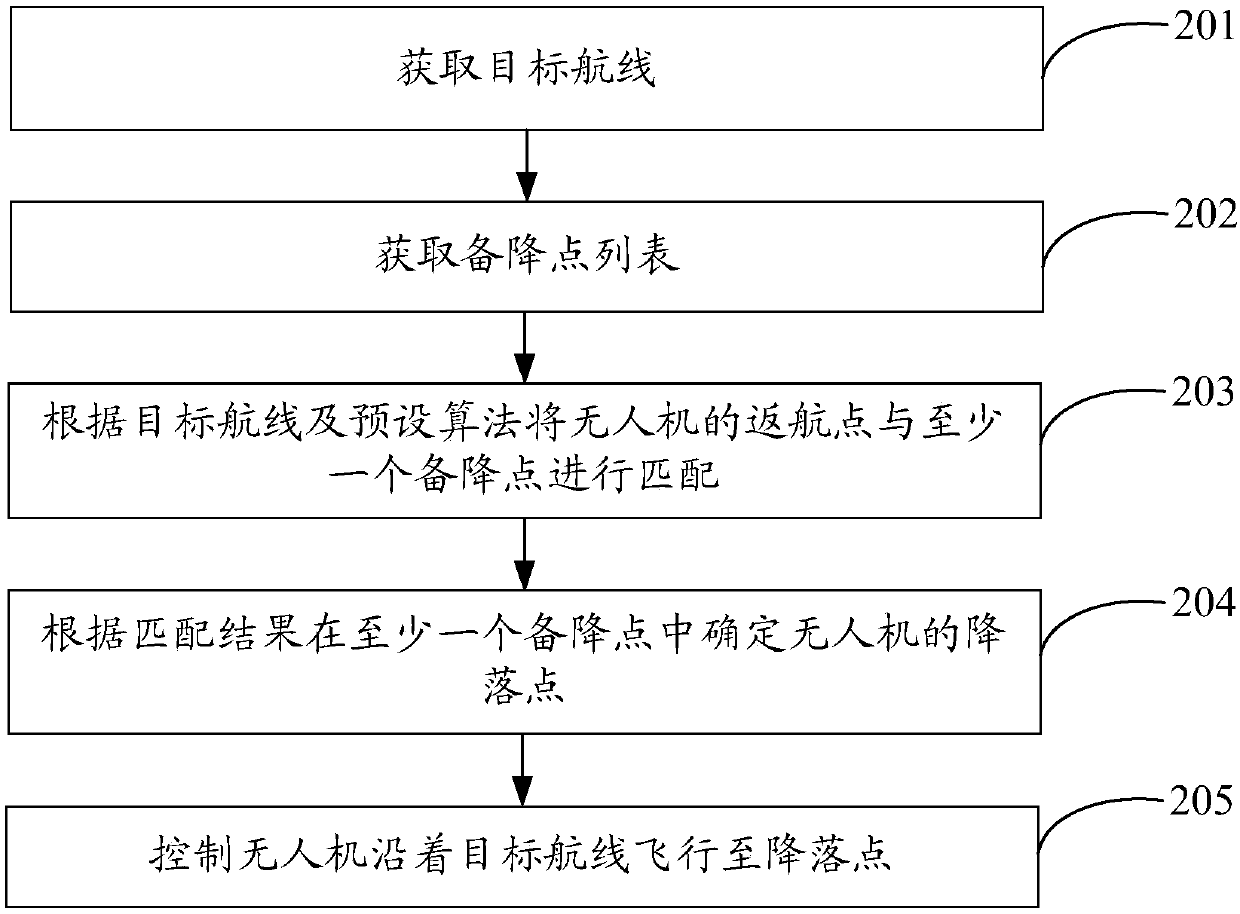
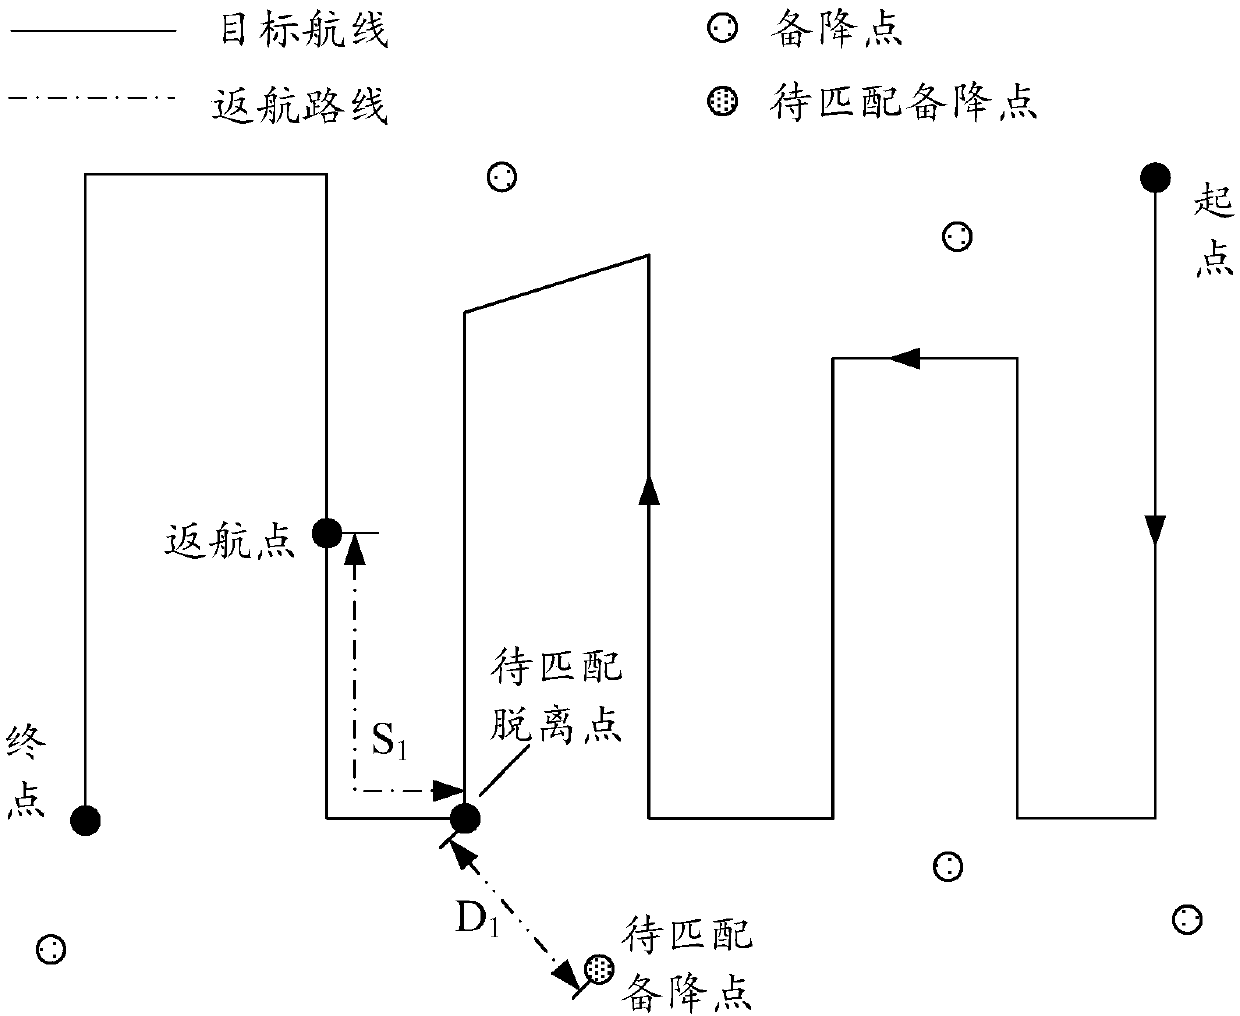
The invention provides a course reversal method and device of an unmanned aerial vehicle, and relates to the field of unmanned aerial vehicles. The problem that an unmanned aerial vehicle has a relatively large risk in a flight process of flying to a standby landing point. The specific technical scheme is as follows: acquiring a target route, wherein the target route is a flight route of a currently executed flight task of the unmanned aerial vehicle; acquiring a standby landing point list, wherein the standby landing point list comprises at least one standby landing point; matching a course reversal point of the unmanned aerial vehicle with the at least one standby landing point according to the target route and a preset algorithm; determining a landing point of the unmanned aerial vehicle from the at least one standby landing point according to a matching result; and controlling the unmanned aerial vehicle to fly to the landing point along the target route. The unmanned aerial vehicle course reversal method and device provided by the invention are applied to course reversal of unmanned aerial vehicles.
Owner:杭州慧郡科技有限公司
Bird abnormal behavior identification method based on radar monitoring data
ActiveCN119272154AEasy to identify accuratelyGuaranteed recognition accuracyArtificial lifeData setData information
The invention discloses a bird abnormal behavior recognition method based on radar monitoring data, belongs to the technical field of target detection, and solves the problem that target recognition precision is affected due to incomplete target single image data information acquired by a data acquisition module of an existing system. A bird sensing model performs correlation analysis on the normalized data set, whether a target object is a bird target object is judged, a target object path track is generated based on a target object recognition result and a path optimization algorithm, and the path track of the target object is analyzed and calculated in combination with a weak supervision bird detection algorithm to generate a path anomaly degree; the bird sensing model can analyze and recognize the bird flight path based on the target object recognition result, and judges and recognizes the bird abnormal behavior in combination with the weak supervision bird detection algorithm, so that the recognition precision of the target object is ensured, and the early warning capability of the bird abnormal behavior is improved.

Owner:ZHONGAN RUIDA (BEIJING) ELECTRONIC TECH CO LTD
Design method for fixed-wing air survey type unmanned aerial vehicle
InactiveCN104401504AGuaranteed liftingGuaranteed firmnessSpecial data processing applicationsGround installationsEngineeringHigh load
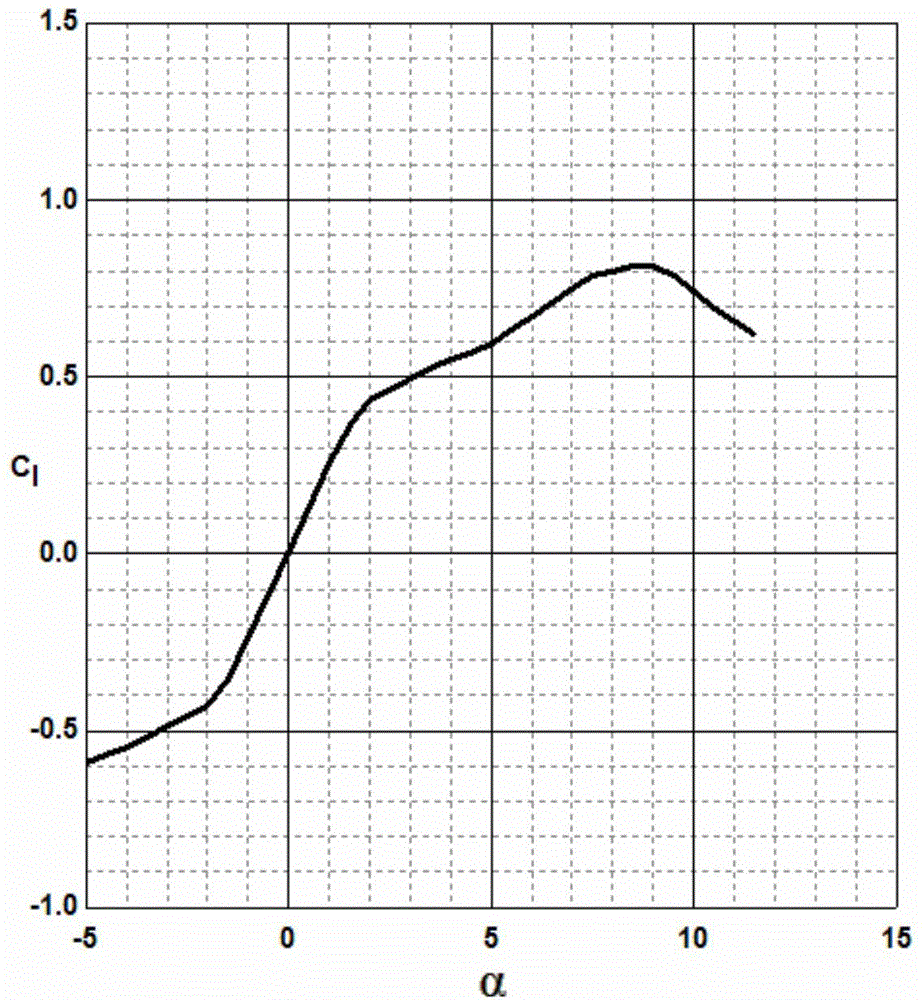
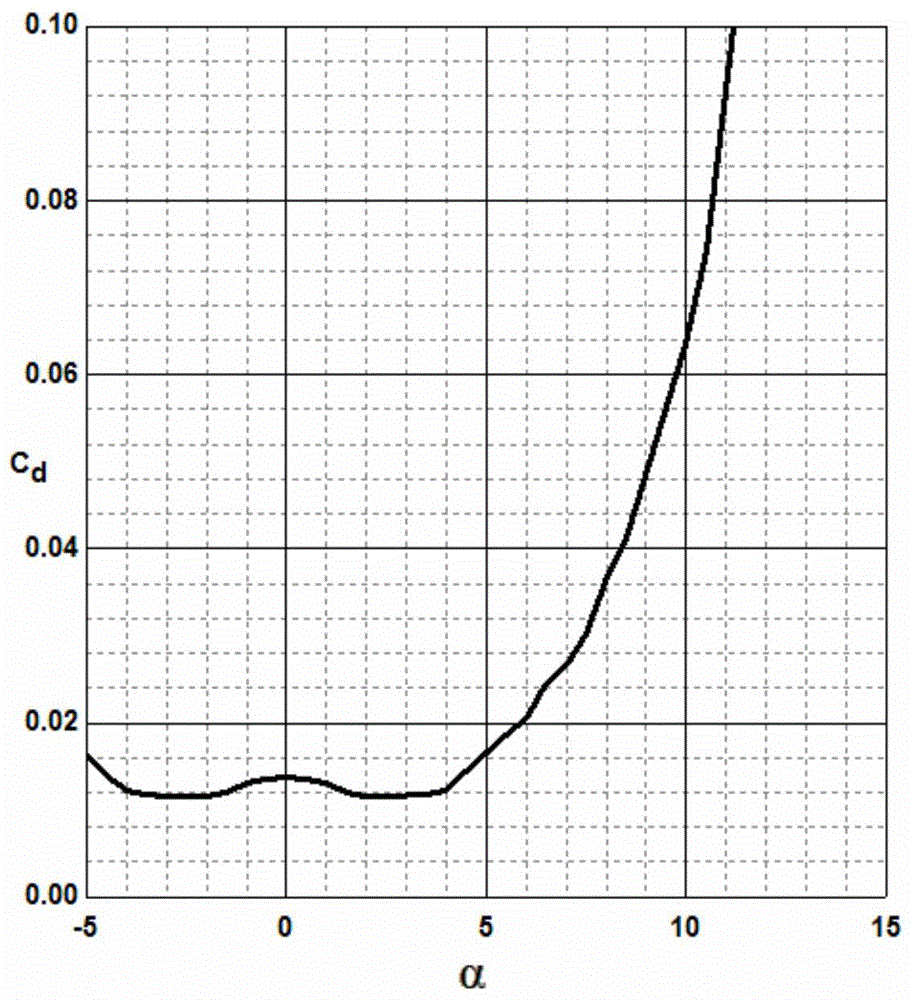
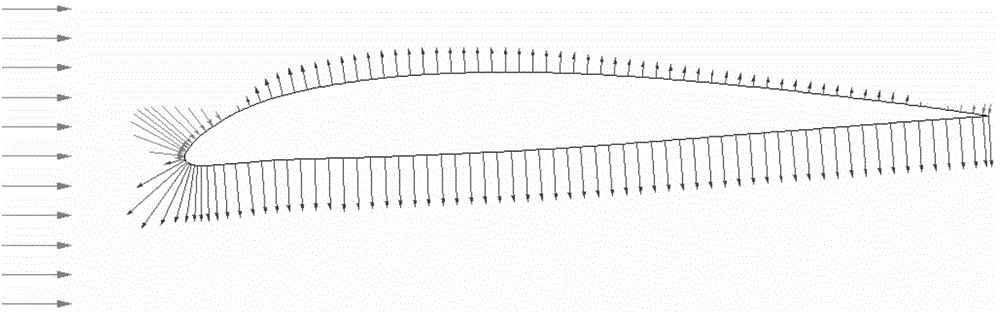
The invention provides a design method for a fixed-wing air survey type unmanned aerial vehicle. The method comprises the following steps: based on a vehicle structure and the working performance, designing the wing profile and a vehicle body; analyzing designed parameters through a Profili software model; drawing a base drawing in CAD (Computer-Aid Design); performing 3D modeling on the drawn base drawing in SketchUP; printing a drawing for manual manufacturing after obtaining a vehicle-mounted 3D model in order to obtain an XW-06 air survey type unmanned aerial vehicle which is low in cost, is easy to operate, and has high stability. The unmanned aerial vehicle manufactured through the design method provided by the invention is low in cost, and has high load capacity; high interference resistance and high stability can be realized specific to different weather conditions, and user-friendly man-machine interactivity is realized.
Owner:CHINA UNIV OF GEOSCIENCES (WUHAN)
Path planning method for unmanned aerial vehicle power grid inspection operation based on Beidou navigation
ActiveCN119146973Areduce flight riskGuaranteed smoothnessNavigational calculation instrumentsSatellite radio beaconingSimulationUncrewed vehicle
The invention relates to the technical field of unmanned aerial vehicle path control, and particularly discloses an unmanned aerial vehicle power grid inspection operation path planning method based on Beidou navigation, and the method comprises the steps: obtaining the historical inspection contribution value of each region of a power grid, and combining the actual operation state contribution value of each region of the power grid; determining an unmanned aerial vehicle power grid inspection operation priority value of each region of the power grid, determining an unmanned aerial vehicle power grid inspection operation initial path, determining an unmanned aerial vehicle power grid inspection operation height of each region of the power grid, and obtaining obstacle position coordinates of a connection path of each region of the power grid based on Beidou navigation; according to the method, the problems that a traditional path planning method cannot meet efficient and intelligent routing inspection requirements and is insufficient in dynamic optimization capability in combination with real-time data are solved, the routing inspection effectiveness is improved, and the routing inspection efficiency is improved. The flight risk of the unmanned aerial vehicle is reduced and the inspection task is smoothly carried out.

Owner:BEIJING HUALIAN POWER ENG SUPERVISION CO +2
Unmanned aerial vehicle visual guidance obstacle avoidance system and method based on polarization information
ActiveCN119396180AHigh precisionhigh speedInternal combustion piston enginesVehicle position/course/altitude controlFeature extractionUncrewed vehicle
The invention discloses an unmanned aerial vehicle visual guidance obstacle avoidance system and method based on polarization information, and relates to the technical field of unmanned aerial vehicle navigation and obstacle avoidance. Polarization image information in a flight scene is collected in real time through a polarization sensor, and the perception capability of a complex environment is enhanced. Polarization parameters are extracted through a compression observation method, the efficiency and accuracy of feature extraction are improved, a visual attention mechanism is combined, an obstacle background area is accurately recognized, a self-adaptive decision fusion model is constructed, the feature weight is optimized, and the reliability of target contour features is enhanced. Preliminary path search is carried out based on target contour features, and a centralized optimization sampling method is adopted, so that the probability of generating an optimal flight path in a complex environment is effectively improved. And the obstacle avoidance flight module is used for smoothing the flight path, so that the smoothness and controllability of the flight path are ensured, and the navigation and obstacle avoidance capabilities of the unmanned aerial vehicle in a complex environment are effectively improved.

Owner:JIANGSU URBAN & RURAL CONSTR VOCATIONAL COLLEGE
Method for transmitting release data between terminals of EFB system based on airdrop function
InactiveCN108769120ARelieve pressureFast dataTransmissionShort range communication serviceData synchronizationTraffic capacity
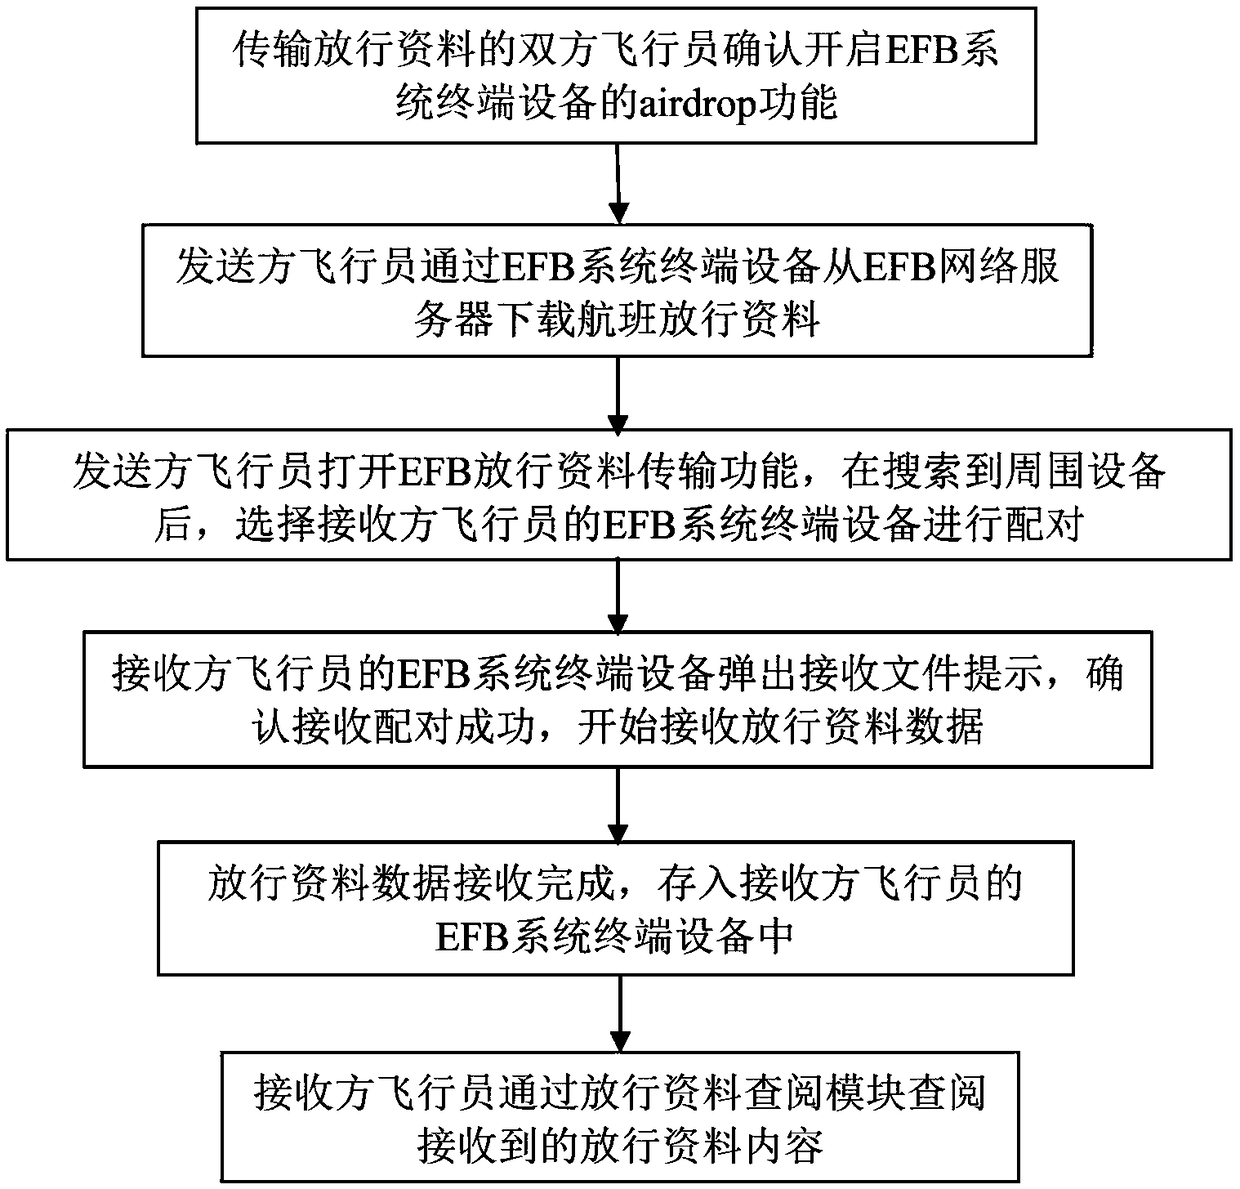
The invention discloses a method for transmitting release data between terminals of an EFB system based on an airdrop function, which mainly uses the airdrop function of an EFB terminal device such asan iPad to transmit the release data in an electronic flight bag (EFB) between pilots. This function is mainly applied to the electronic flight package software EFB system in civil aviation flight. The release data may be shared with other pilots of the same unit after being downloaded by a person in a unit, thereby achieving the purpose of quick data synchronization and traffic saving, avoidingall crew members from downloading data from the server, saving traffic, and reducing the server pressure. The release data between crew members may be synchronized without relying on the network, which saves download traffic and reduces flight preparation time for international flights. The invention is fast in transmission speed, stable, and small in interference, and the release data may be gotthrough this method for the situation that the release data cannot be opened or downloaded for some reasons, thereby reducing the risk of flight.
Owner:中航材导航技术(北京)有限公司
Unmanned aerial vehicle flight path planning method based on infrastructure data
PendingCN119509539Areduce flight riskGuaranteed adaptabilityNavigational calculation instrumentsSimulationData acquisition
The invention discloses an unmanned aerial vehicle route planning method based on capital construction data. The method comprises the following steps: step 1, data acquisition and arrangement; 2, performing three-dimensional modeling; step 3, preliminarily generating a route; 4, checking and optimizing the air route; and 5, simulating test flight. Through introduction of real-time dynamic data and application of an intelligent algorithm, the scheme effectively prevents the unmanned aerial vehicle from encountering obstacles and unsuitable areas in the flight process, significantly reduces the flight risk, can update the flight path plan in real time, ensures that the flight path of the unmanned aerial vehicle keeps adaptability under changing meteorological conditions and traffic flow, and improves the flight speed. The flight task is more flexible and efficient, and the flight time and energy consumption of the unmanned aerial vehicle can be reduced through an intelligent optimization algorithm and scheme, so that the task execution efficiency is improved, the operation cost is reduced, and higher economy and benefits are provided for the application of the unmanned aerial vehicle.

Owner:CONSTR BRANCH OF STATE GRID JIANGSU ELECTRIC POWER CO LTD
Unmanned aerial vehicle management and control method and system based on Beidou grid code, and computing device
PendingCN119536364Areduce flight riskaccurate divisionVehicle position/course/altitude controlPosition/direction controlSimulationUncrewed vehicle
The invention discloses an unmanned aerial vehicle management and control method and system based on Beidou grid codes, and a computing device. The method comprises the steps of determining a ground area corresponding to an area suitable for flight; acquiring ground elevation information of the ground area, and extending upwards by a predetermined height based on the ground elevation information to form a flight space area of the unmanned aerial vehicle; performing grid division on the flight space area based on the Beidou grid code so as to divide the flight space area into a plurality of space grid units; periodically acquiring flight information of the unmanned aerial vehicle; based on the flight information of each unmanned aerial vehicle, allocating a corresponding low-altitude task to each subordinate unmanned aerial vehicle through the master control unmanned aerial vehicle, and sending a control instruction to each subordinate unmanned aerial vehicle to control each subordinate unmanned aerial vehicle to execute the low-altitude task; and determining each space grid unit corresponding to the space position information of the unmanned aerial vehicle at each time point, and generating a grid flight path of the unmanned aerial vehicle so as to monitor and manage the flight process of the unmanned aerial vehicle based on the grid flight path.

Owner:BEIJING ZHIWANG YILIAN TECH CO LTD
Locking mechanism of cabin door and alarming system thereof
ActiveCN107060545AIncrease preloadImprove connection strengthWing fastenersAlarmsLocking mechanismEngineering
The invention provides a locking mechanism of a cabin door and an alarming system of the locking mechanism of the cabin door and relates to the technical field of rotorcrafts. The locking mechanism of the cabin door and the alarming mechanism of the locking mechanism of the cabin door solve the technical problems that a locking mechanism of the cabin door is inconvenient to open and close and cannot remind people that whether the door is locked well or not, then flight danger is caused. The locking mechanism of the cabin door comprises a locking seat and a hooking connection piece. The locking seat is fixedly arranged on a cabin body. The hooking connection piece is movably connected to the cabin door. The locking seat comprises an installation seat and a clamping lock column. The hooking connection piece comprises a door inner handle, a hook, a door outer handle and a connecting shaft. A trigger portion is arranged on the hook. The locking mechanism of the cabin door further comprises the alarming system. The alarming system comprises a trigger switch, an electronic alarm and a control unit. When the hook is clamped to the clamping lock column, the trigger portion is in contact with and in connection with the trigger switch and used for switching off the electronic alarm. The locking mechanism of the cabin door and the alarming mechanism of the locking mechanism of the cabin door have the advantages of being simple in structure, tight in clamping, good in clamping effect and convenient to operate. The alarming system can remind people whether the cabin door is locked well or not and lower the flight risk.


Owner:河北天启通宇航空器材科技发展有限公司
Unmanned aerial vehicle real-time path planning system based on dynamic environment perception
PendingCN119394306Aaccurate perceptionreduce flight riskResource allocationNavigational calculation instrumentsReal-time dataControl system
The invention provides an unmanned aerial vehicle real-time path planning system based on dynamic environment perception, and the system comprises the steps: firstly carrying out environment perception and data acquisition: employing a sensor to obtain the data of a surrounding environment in real time, carrying out the edge calculation and cloud data processing, and guaranteeing the real-time performance and accuracy; and then path planning and decision support are carried out: path planning is carried out by combining machine learning and an optimization method based on environment perception data, and an optimal flight path is rapidly and dynamically generated. And finally, performing real-time execution and control: after the path planning is completed, enabling the unmanned aerial vehicle to accurately fly according to a preset path through an autonomous navigation and control system, and performing real-time adjustment when needed. According to the invention, the advanced sensing technology and the real-time data processing capability are utilized, dynamic flight path planning and optimization are provided for the unmanned aerial vehicle in a changeable and unpredictable environment, and the safety and efficiency of task execution are ensured.
Owner:NANJING INTELLIGENT BIG DRONE INST OF TECH LTD
Helicopter collective pitch channel control force trend sensing emergency system and control method
ActiveCN119225231AEnsure flight safetyprotect lifeProgramme controlComputer controlData controlClassical mechanics
The invention belongs to the field of helicopter flight control, and particularly relates to a helicopter collective pitch channel control force trend sensing emergency system and a control method, the system comprises a collective pitch rod force sensor (1), a data processing module box (3), a control force emergency control module (4) and a collective pitch steering engine (5); the collective distance rod force sensor (1) is installed on a collective distance rod and used for measuring the operating force of the collective distance rod and sending measured data to the data processing module box. The total pitch steering engine is connected with the total pitch rod in parallel through a connecting rod; the data processing module box processes the operating force data of the collective distance rod and then sends the operating force data to the operating force emergency control module; and the operating force emergency control module controls the collective pitch steering engine (5) to work according to the operating force data of the collective pitch rod.

Owner:CHINA HELICOPTER RES & DEV INST
Unmanned aerial vehicle inspection path planning method based on artificial intelligence, medium and server
PendingCN119414878AReduce the burden onImprove inspection efficiencyNavigational calculation instrumentsPicture taking arrangementsTransmission towerAlgorithm
The invention provides an unmanned aerial vehicle routing inspection path planning method based on artificial intelligence, a medium and a server, and the method comprises the steps: obtaining an initial routing inspection path in a power routing inspection region, the initial routing inspection path being a double-side routing inspection path, and a power transmission cable at each side corresponding to a single-side routing inspection path, each single-side inspection path comprises a plurality of I-class inspection path segments for performing power inspection on the power transmission towers and II-class inspection path segments for performing power inspection along power transmission cables between two adjacent power transmission towers, and the I-class inspection path segments and the II-class inspection path segments are connected in sequence; and for a current inspection path segment where the unmanned aerial vehicle is located, obtaining electric power inspection data of the unmanned aerial vehicle in a current time period, and adjusting the current inspection path segment based on the electric power inspection data in the current time period, so that the unmanned aerial vehicle performs electric power inspection based on the adjusted inspection path segment, the power inspection data comprises position data, attitude data and state data of the unmanned aerial vehicle and image data shot by the unmanned aerial vehicle.

Owner:STATE GRID JIANGSU ELECTRIC POWER CO LTD SUZHOU BRANCH +1
An unmanned aerial vehicle hoisting task optimization method and device
The application discloses a kind of unmanned aerial vehicle hoisting task optimization method and device, and the application relates to unmanned aerial vehicle scheduling technical field, comprising the following steps: based on hoisting starting point and target construction site determines hoisting path boundary, and the point cloud data of this area is collected, set along the way node, obtain the signal strength of each node and analyze its fluctuation, filter out the effective path point of signal stability, according to the distance of effective path point and target construction site Priority is set, with hoisting starting point as center, determine search range, select several candidate nodes from it, and collect wind speed variation, terrain complexity and cargo swing angle, calculate the risk cost of each node, select the candidate node with the lowest risk cost as the next waypoint, update the current effective path point of unmanned aerial vehicle, until unmanned aerial vehicle reaches target construction site, complete hoisting transport task, realize more safe and reliable transport movement.

Owner:SINOHYDRO BUREAU 14 CO LTD +1
UAV magnetic interference calibration method and distributed magnetic anomaly detection system
ActiveCN111220932BReduce flight riskHigh precisionElectric/magnetic detectionMagnitude/direction of magnetic fieldsMagnetic disturbanceComputational physics
The invention provides a method for calibrating magnetic interference of UAV and a distributed magnetic anomaly detection system. The method includes: placing the UAV horizontally on the ground, measuring the geomagnetic field vector, installing the first magnetometer on the ground; installing the second Two magnetometers; with the first magnetometer as the center of rotation, rotate the drone clockwise and sequentially measure the first magnetic field difference value in 8 directions and the first angle between the geomagnetic field vector and the coordinate axis of the drone; Flip the drone 180° along the horizontal axis of symmetry and place it on the ground, install the third magnetometer on the ground; take the third magnetometer as the rotation center, rotate the drone clockwise and measure the second magnetometer in 8 directions in sequence. The magnetic field difference value and the second angle between the geomagnetic field vector and the UAV coordinate axis; calculate the UAV magnetic interference coefficient to complete the UAV magnetic interference calibration. Applying the technical solution of the present invention can solve the technical problems in the prior art that the unmanned aerial vehicle magnetic interference calibration method is complicated to operate, the operation risk is relatively high, and the accuracy of magnetic interference calibration is low.


Owner:BEIJING AUTOMATION CONTROL EQUIP INST
A kind of warning method of refueling fuel quantity
ActiveCN109625300BKnow the flight status in real timeAccurate follow-up flight planningGround installationsDisplay deviceFuel oil
The present application discloses a method for warning the refueling quantity of a refueling machine, which includes: acquiring airport information and current location information, current remaining fuel quantity, information on external storage items, and obtaining the current location information of the refueling machine and the remaining refueling quantity of the refueling machine; Calculate the maximum voyage circle of the oil receiver according to the current position information and the airport position information, and calculate the refueling amount required by the oil receiver from the nearest airport according to the store information, current position information and airport position information; display the airport on the display device Location, the current position of the receiver, the maximum voyage circle of the receiver, the amount of refueling required by the receiver, the current position information of the tanker, and the remaining refueling capacity of the tanker. The application calculates and displays the maximum voyage circle that the aircraft can achieve by using the existing fuel quantity in real time, which helps the pilot to understand the voyage status of the aircraft in real time more intuitively.


Owner:SHENYANG AIRCRAFT DESIGN INST AVIATION IND CORP OF CHINA
Simulation deformation aircraft and control method
ActiveCN119272421Aimprove securityeasy to moveGeometric CADSustainable transportationFlight vehicleSimulation
The invention relates to the technical field of aircraft control, in particular to a simulation deformation aircraft and a control method. Comprising the following steps: S1, acquiring parameter data of an aircraft, dividing the moving form of the aircraft into a flight mode and a ground mode according to the parameter data, and then summarizing to establish an aircraft form database; s2, performing aerial measurement and investigation in the moving process of the aircraft, acquiring surrounding environment data of the aircraft, and then extracting a movable path by combining the surrounding environment data with the aircraft form database; s3, extracting a qualified moving form corresponding to the movable path; a navigation path is generated by combining a real-time position of an aircraft and a movable path selected by a user, and is continuously optimized in a simulation process, and an optimal moving path and form combination is selected by performing performance evaluation and comprehensive scoring on different moving forms, so that the most efficient flight is realized.

Owner:FUJIAN FURUIWANG TECH CO LTD
Spin feature analysis method
The present invention relates to a method for analyzing tailspin characteristics. The time history of tailspin characteristics is obtained by solving tailspin dynamics differential equations, and the tailspin characteristics of simulation examples under conditions of multi-parameter changes such as weight, moment of inertia, and entry mode are predicted, and the influence of multi-variable parameters on the tailspin characteristics is analyzed; a machine learning model is built using an XGBoost regression algorithm based on decision tree analysis, and the multi-variable parameters of the simulation example are analyzed for feature importance with tailspin characteristics such as average angle of attack, average rotation rate, and sinking speed as targets; the influence ratio of multi-variable parameters on the same tailspin characteristics is analyzed, and the influence of key factors on the tailspin is completed in a quantitative manner. The tailspin feature analysis method of the present invention takes tailspin characteristics as targets, performs feature importance analysis on three multi-variable parameters of weight, moment of inertia, and entry mode, gives the degree of influence of each variable parameter on the corresponding target in the form of quantitative weights, and completes the multi-dimensional global feature analysis of the simulation example.

Owner:NANCHANG HANGKONG UNIVERSITY +1
Electric field avoidance drone
InactiveCN106774414BReduce flight riskGuaranteed work efficiencyPosition/course control in three dimensionsElectric field sensorElectrical field strength
The invention belongs to the technical field of unmanned aerial vehicles and discloses an electric field avoidance type unmanned aerial vehicle. The electric field avoidance type unmanned aerial vehicle comprises an unmanned aerial vehicle body, an electric field sensor, a movable bracket, a bracket driving structure and an electric field measurement controller, wherein the electric field sensor is fixed on the unmanned aerial vehicle body through the movable bracket and is used for sensing electric field intensity in six directions including an upper direction, a lower direction, a left direction, a right direction, a front direction and a back direction by taking the unmanned aerial vehicle body as an original point; the bracket driving structure is connected with the movable bracket and is used for driving the movable bracket to stretch and shrink in the six directions; the electric field measurement controller is connected with the electric field sensor and is used for acquiring electric field measurement data; the electric field measurement controller is connected with the bracket driving structure and is used for controlling the stretching and shrinking of the movable bracket and recording stretching and shrinking quantity; and the electric field measurement controller is connected with a flight controller of the unmanned aerial vehicle body and is used for acquiring control mass and feeding back electric field measurement information and stretching and shrinking quantity information. The electric field avoidance type unmanned aerial vehicle disclosed by the invention is capable of avoiding strong electric fields during the operation.

Owner:EWATT TECH CO LTD
Transmission system of tandem double-rotor unmanned aerial vehicle
ActiveCN224187965Ucompact structureImprove power utilization efficiencyGearboxesToothed gearingsUncrewed vehicleGear train
The utility model relates to a tandem type double-rotor unmanned aerial vehicle transmission system, which is characterized in that reversing speed reduction units of a front rotor and a rear rotor are connected through a plurality of sections of synchronous long shafts, and the tandem type double-rotor unmanned aerial vehicle transmission system comprises a three-stage speed reduction structure, namely a first-stage synchronous belt speed reduction structure, a second-stage bevel gear speed reduction structure and a third-stage planetary gear train speed reduction structure, the second-stage bevel gear speed reduction realizes power transmission through a bevel gear, and the third-stage planetary gear train speed reduction transmits power to a rotor shaft through meshing of a planetary gear, a sun gear and a gear ring; the system solves the problems that a traditional tandem rotorcraft transmission system is single in structure, slow in clutch response, difficult in engine starting, insufficient in power, poor in emergency risk avoiding capacity and difficult to maintain, and the performance and reliability of the unmanned aerial vehicle are improved.

Owner:CHONGQING UNIV
Embedded Air Data Sensing System Information Fusion Ground Verification System
ActiveCN107544454BAchieve correctnessRealize a realistic simulationElectric testing/monitoringClosed loopEngineering
The invention discloses a system for conducting ground-based validation on the information fusion of a flush air data sensing system. The system herein includes an air pressure simulation test systemand a closed-loop test system. The air pressure simulation test system includes an air pressure simulation designated device and a flush air test computer. The air pressure simulation designated device is intended for applying air pressure to respective air pressure measurement channel of the flush air data sensing system. The flush air test computer is intended for acquiring the air pressure value which is transmitted to respective air pressure measurement channel by the air pressure designated device and the corresponding channel measurement value that is output by the flush air data sensingsystem, and acquiring a dynamic response model of different air pressure measurement channels of the flush air data sensing system. The closed-loop test system includes a sensor, a controller, an execution mechanism, a dynamics simulator and a test interpretation system. According to the invention, the system achieves ground-based validation of the information fusion of the flush air data sensingsystem by means of dynamic response difference of multiple air pressure measurement channels.


Owner:BEIJING INST OF CONTROL ENG