

Patents
Literature
42results about How to "Stable driving" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Movable Body Drive Method and Movable Body Drive System, Pattern Formation Method and Pattern Formation Apparatus, and Device Manufacturing Method
InactiveUS20090033900A1High accuracyStable drivingPhotomechanical apparatusUsing optical meansMoving averageServo control
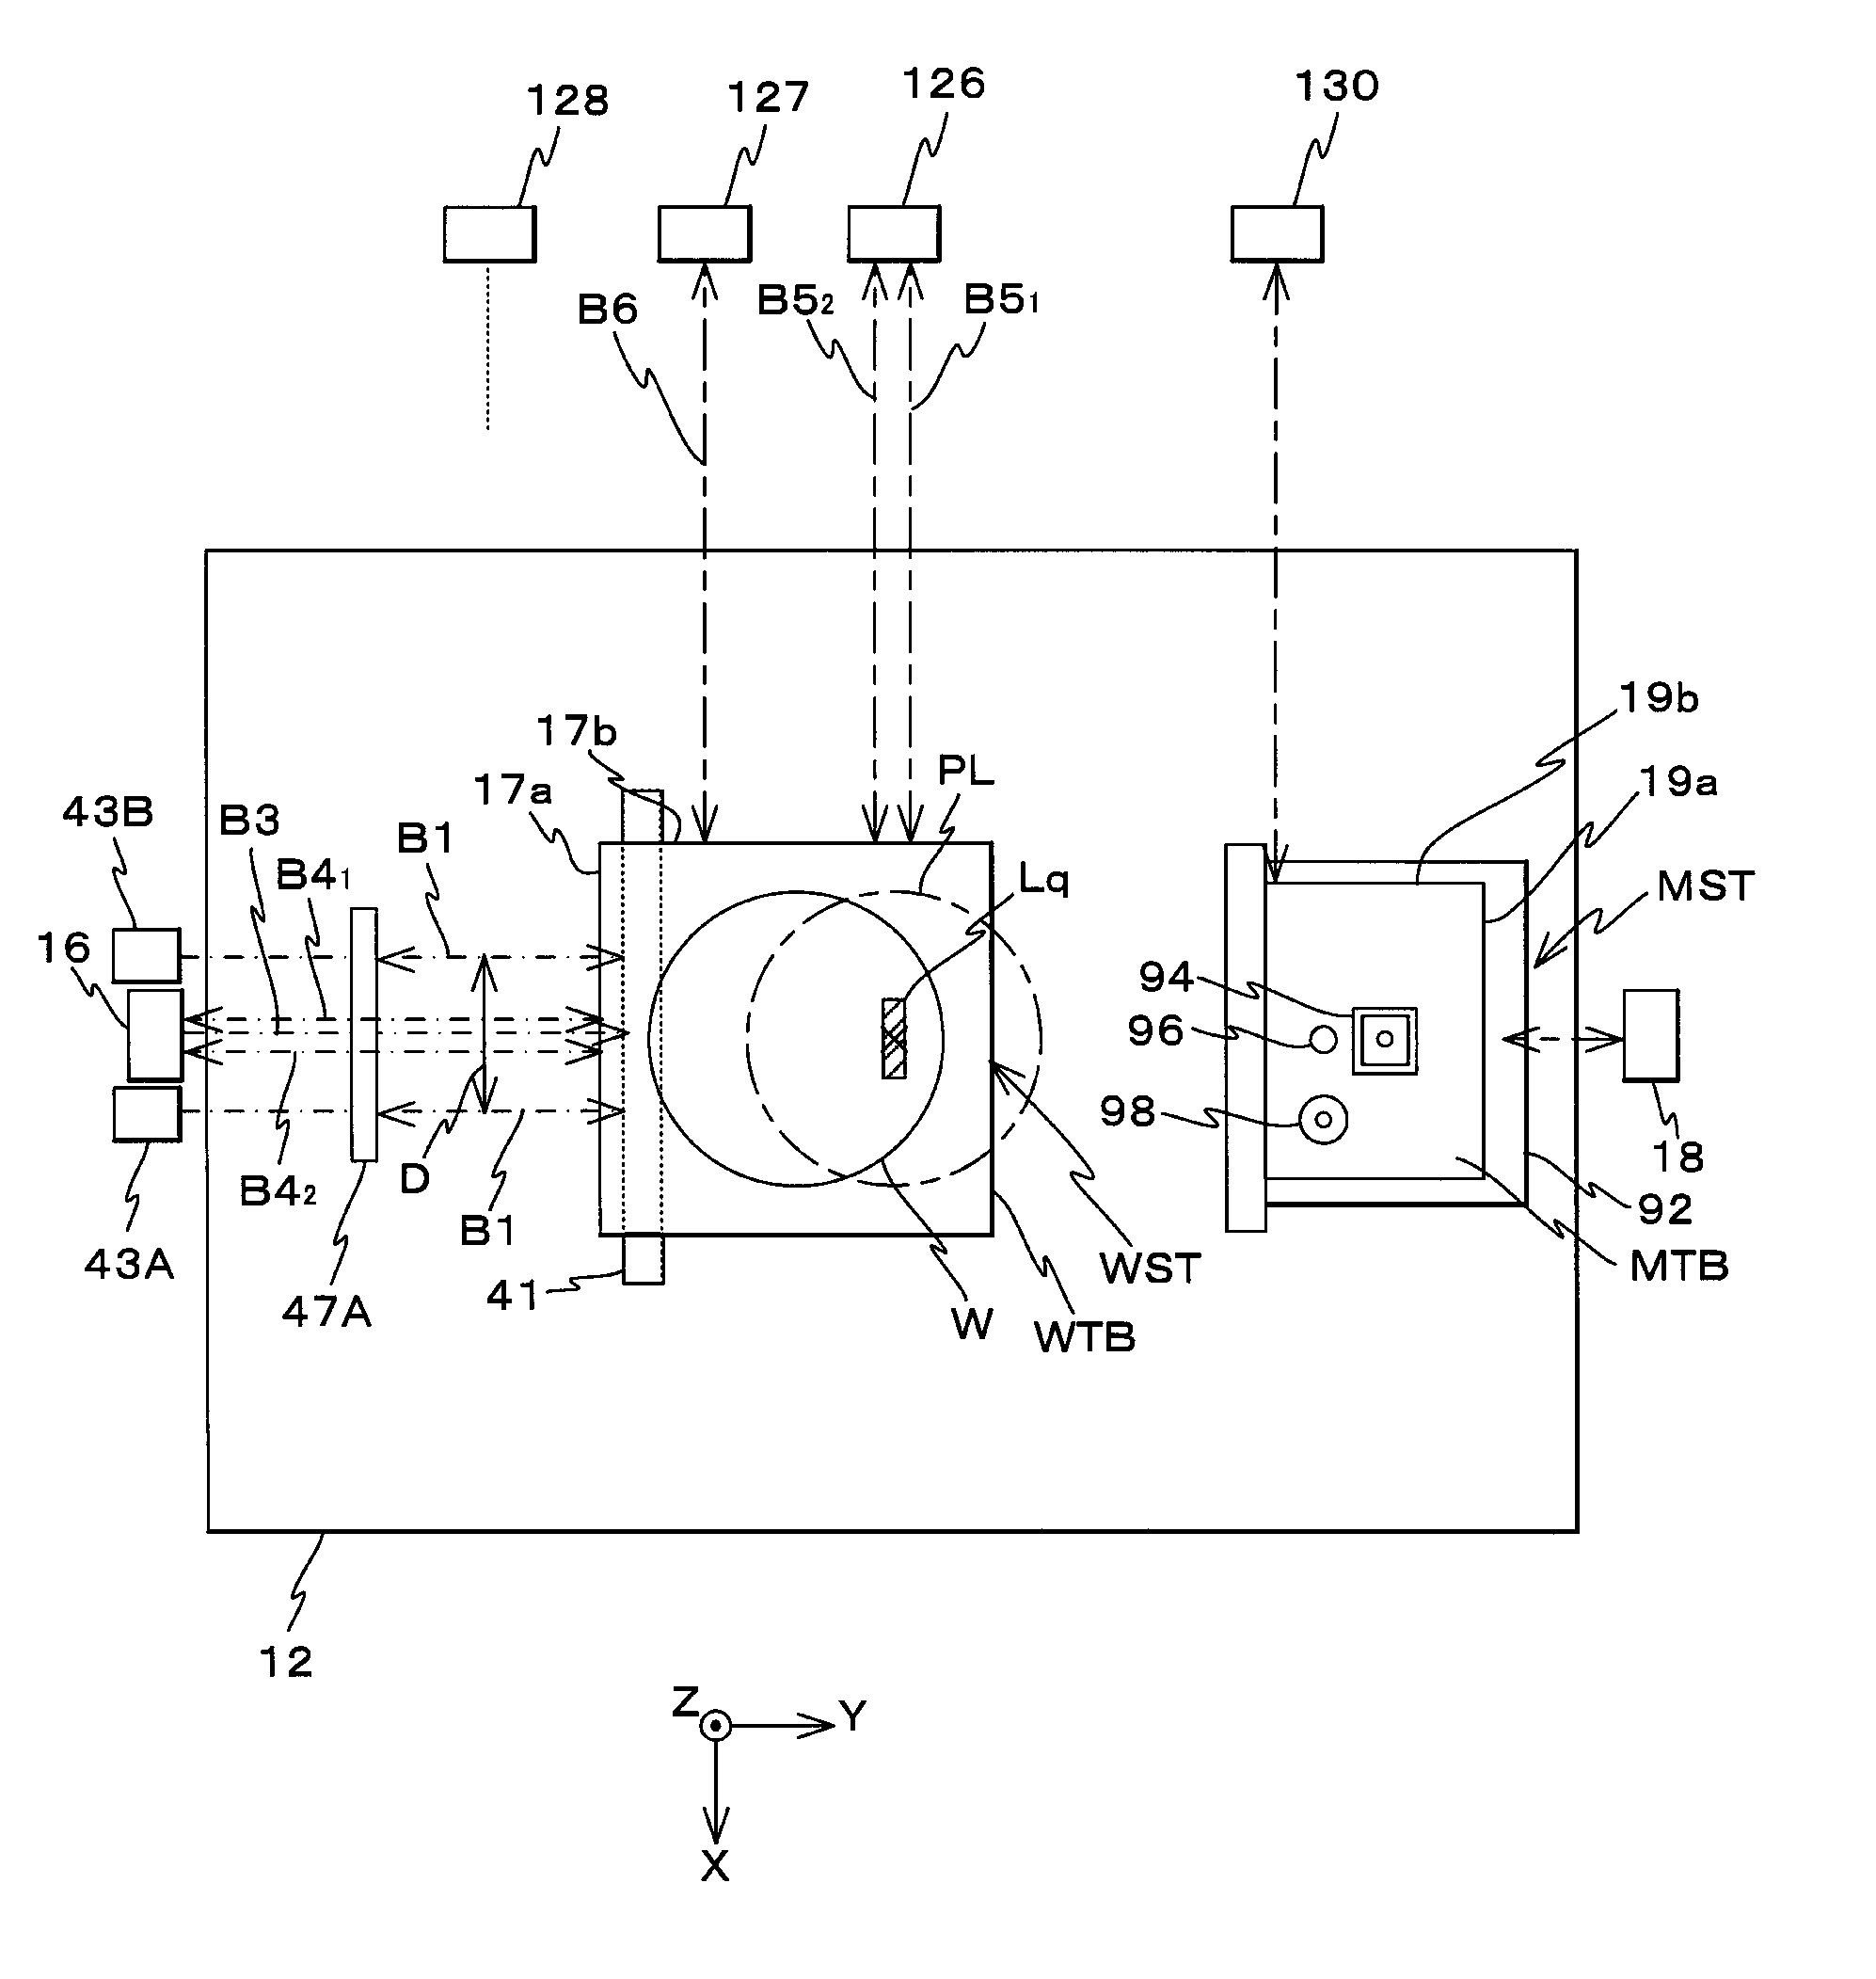
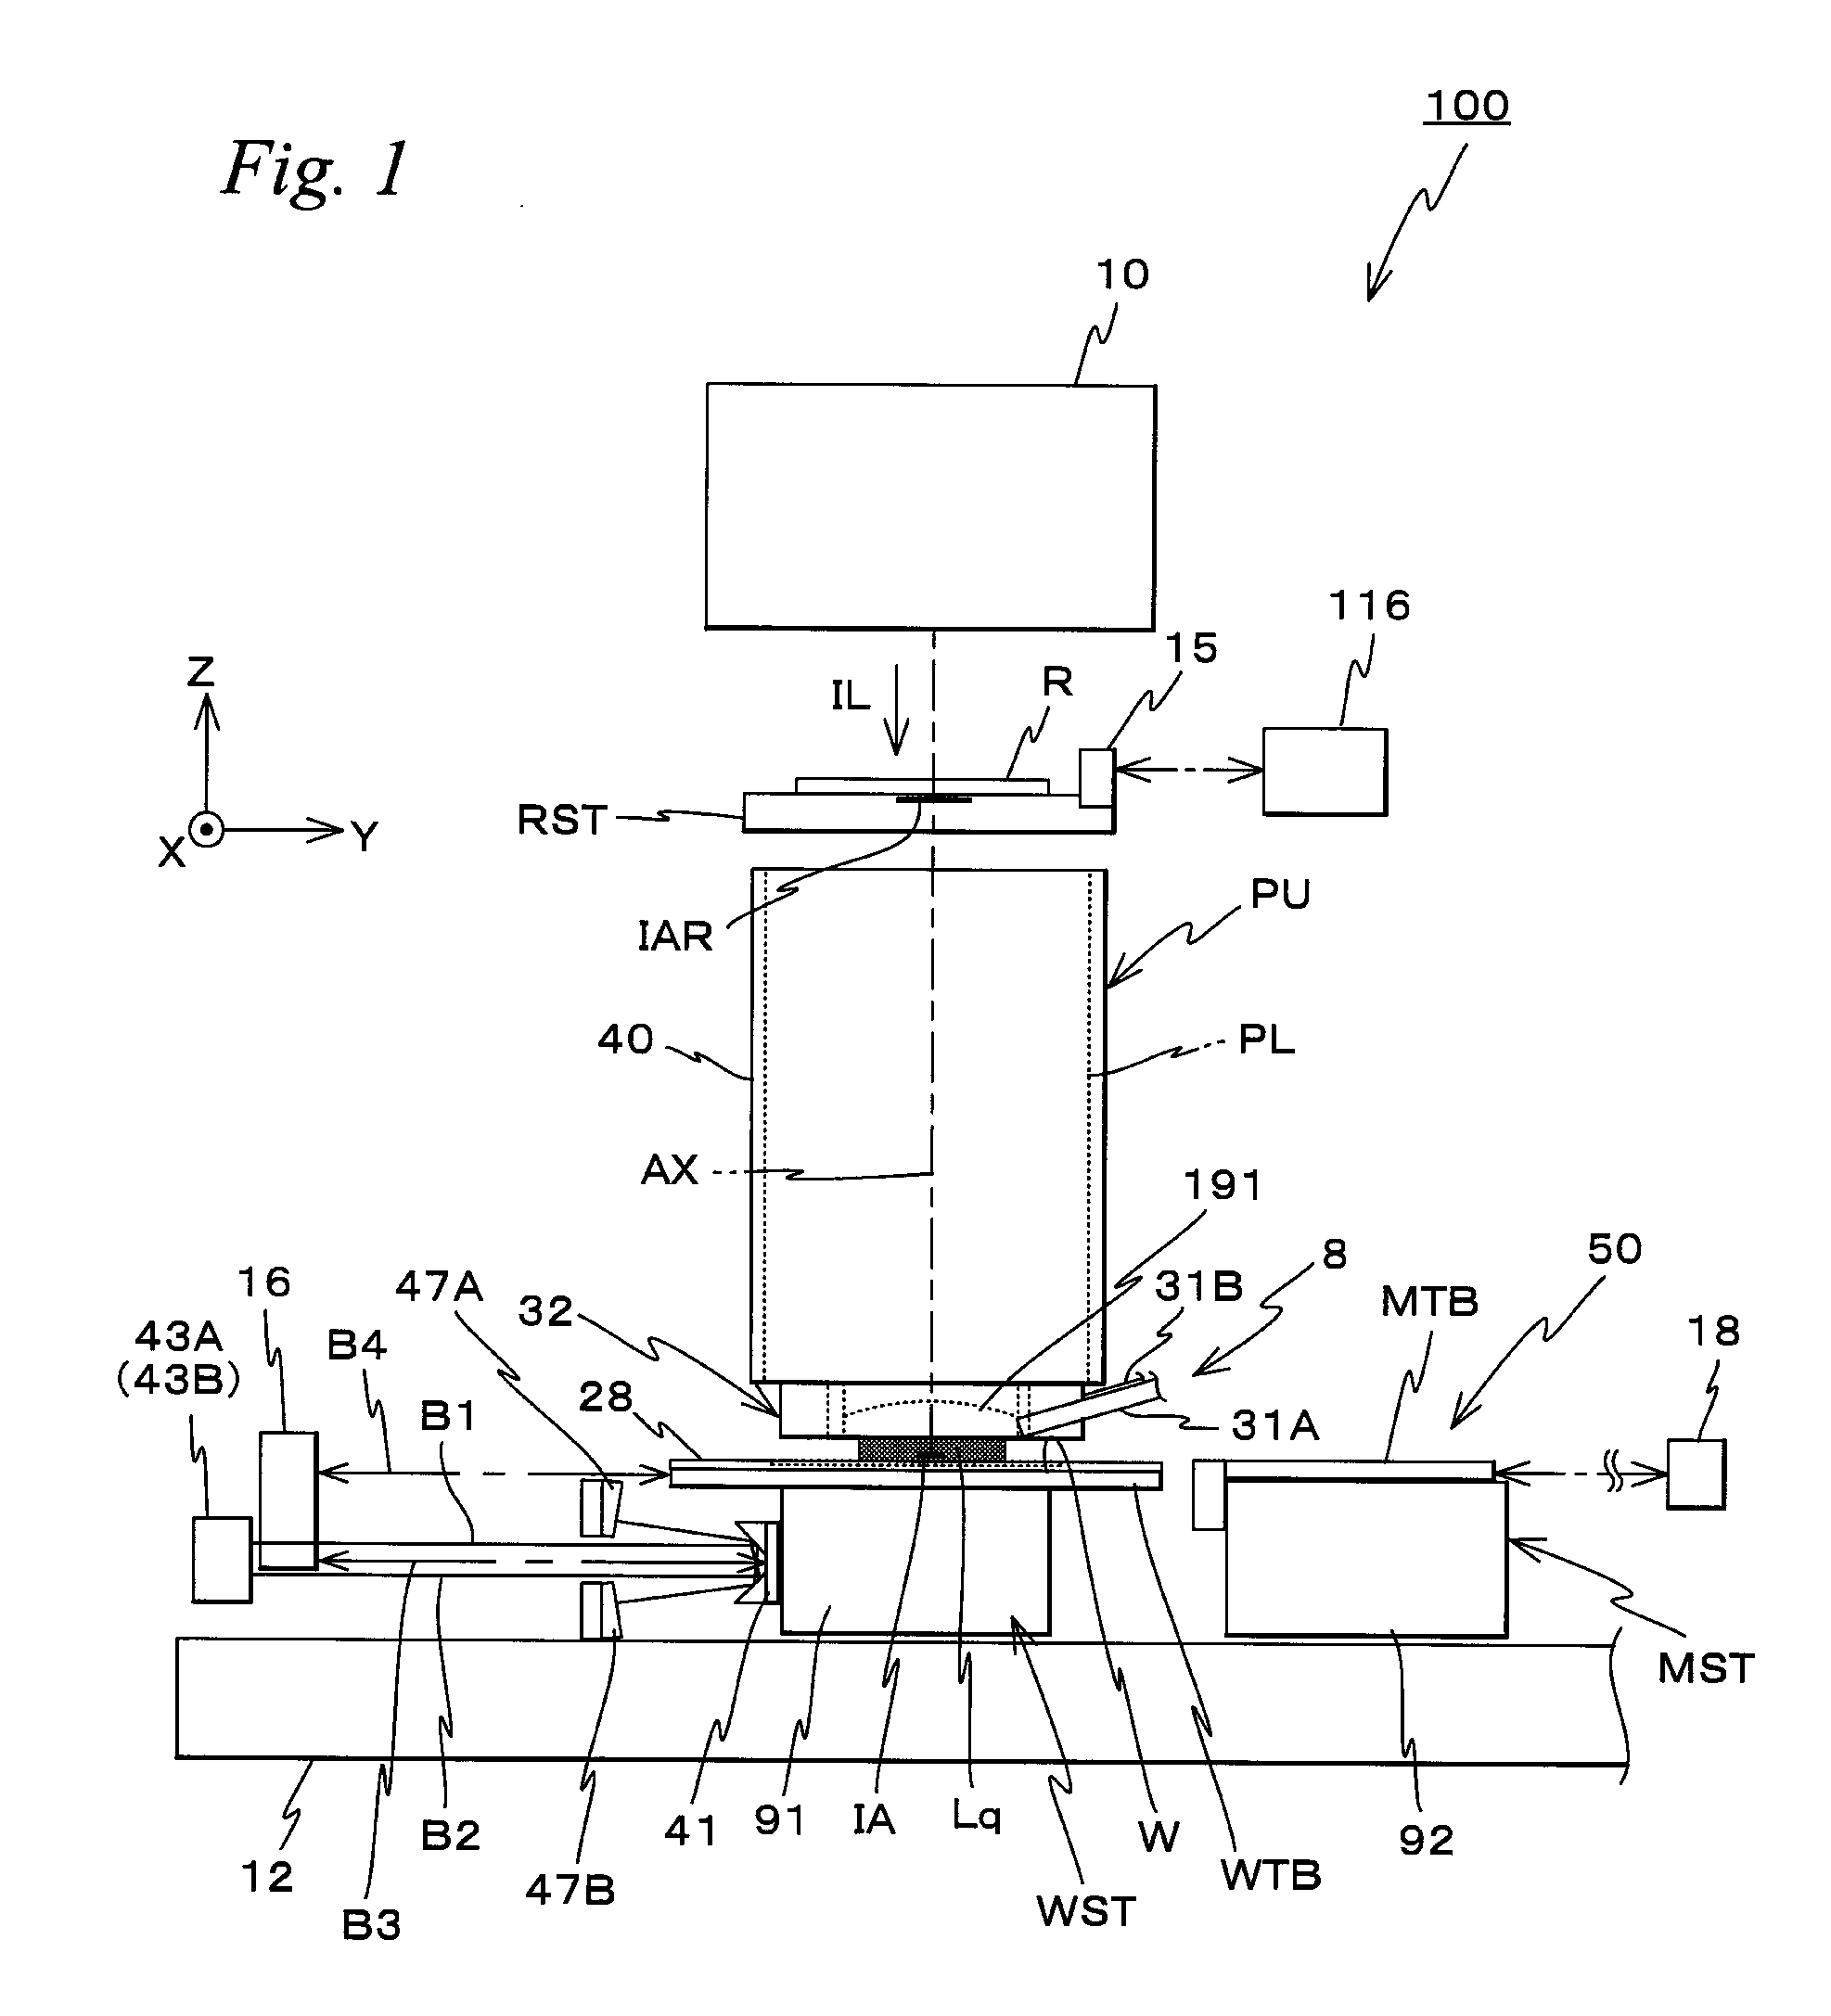
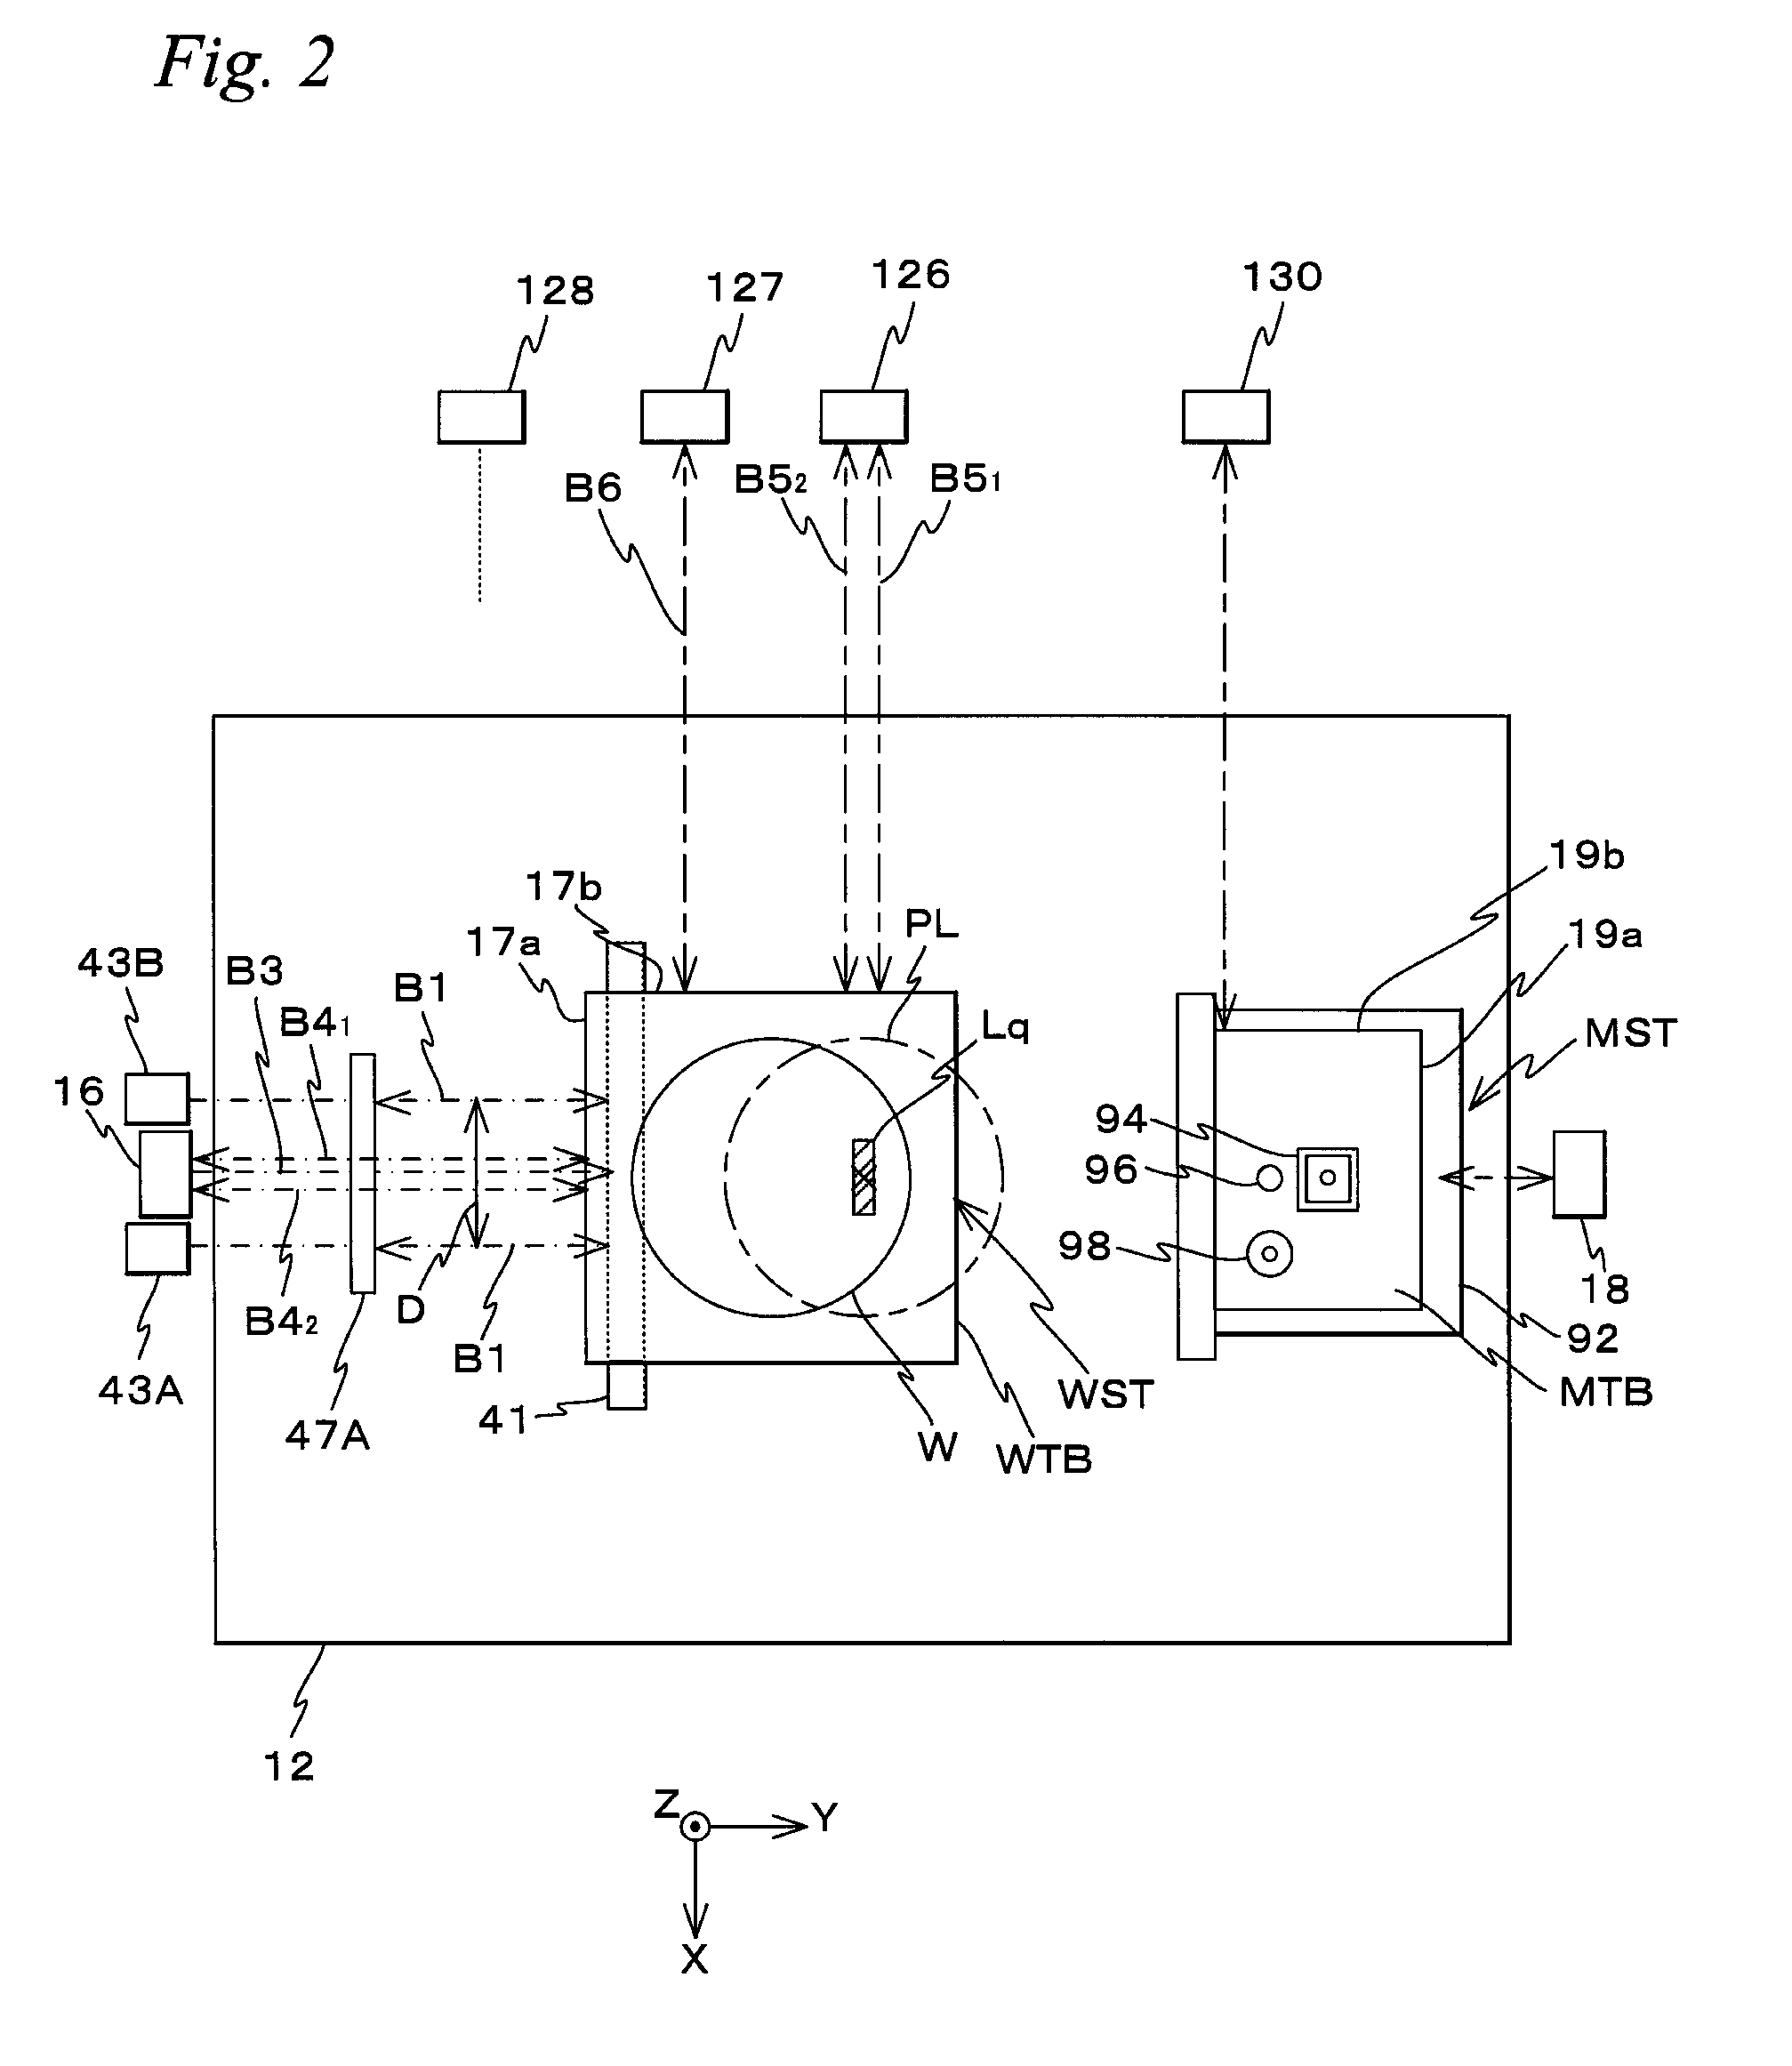
First positional information of a stage is measured using an interferometer system, for example, an X interferometer and a Y interferometer. At the same time, second positional information of the stage is measured using an encoder system, for example, one X head and one Y head. A coordinate offset is set by performing a moving average of the difference between the first positional information and the second positional information for over a predetermined measurement time, and the reliability of output signals of the encoder system is verified using the coordinate offset. In the case the output signals are determined to be normal, the stage is servocontrolled using the sum of the first positional information and the coordinate offset. Such servocontrol by a hybrid method makes it possible to perform drive control of the stage having stability of the interferometer and accuracy of the encoder together.
Owner:NIKON CORP
Lens barrel, camera and mobile information terminal
InactiveUS20090066829A1High degree-of-freedomStable drivingTelevision system detailsPrintersCamera lensCam
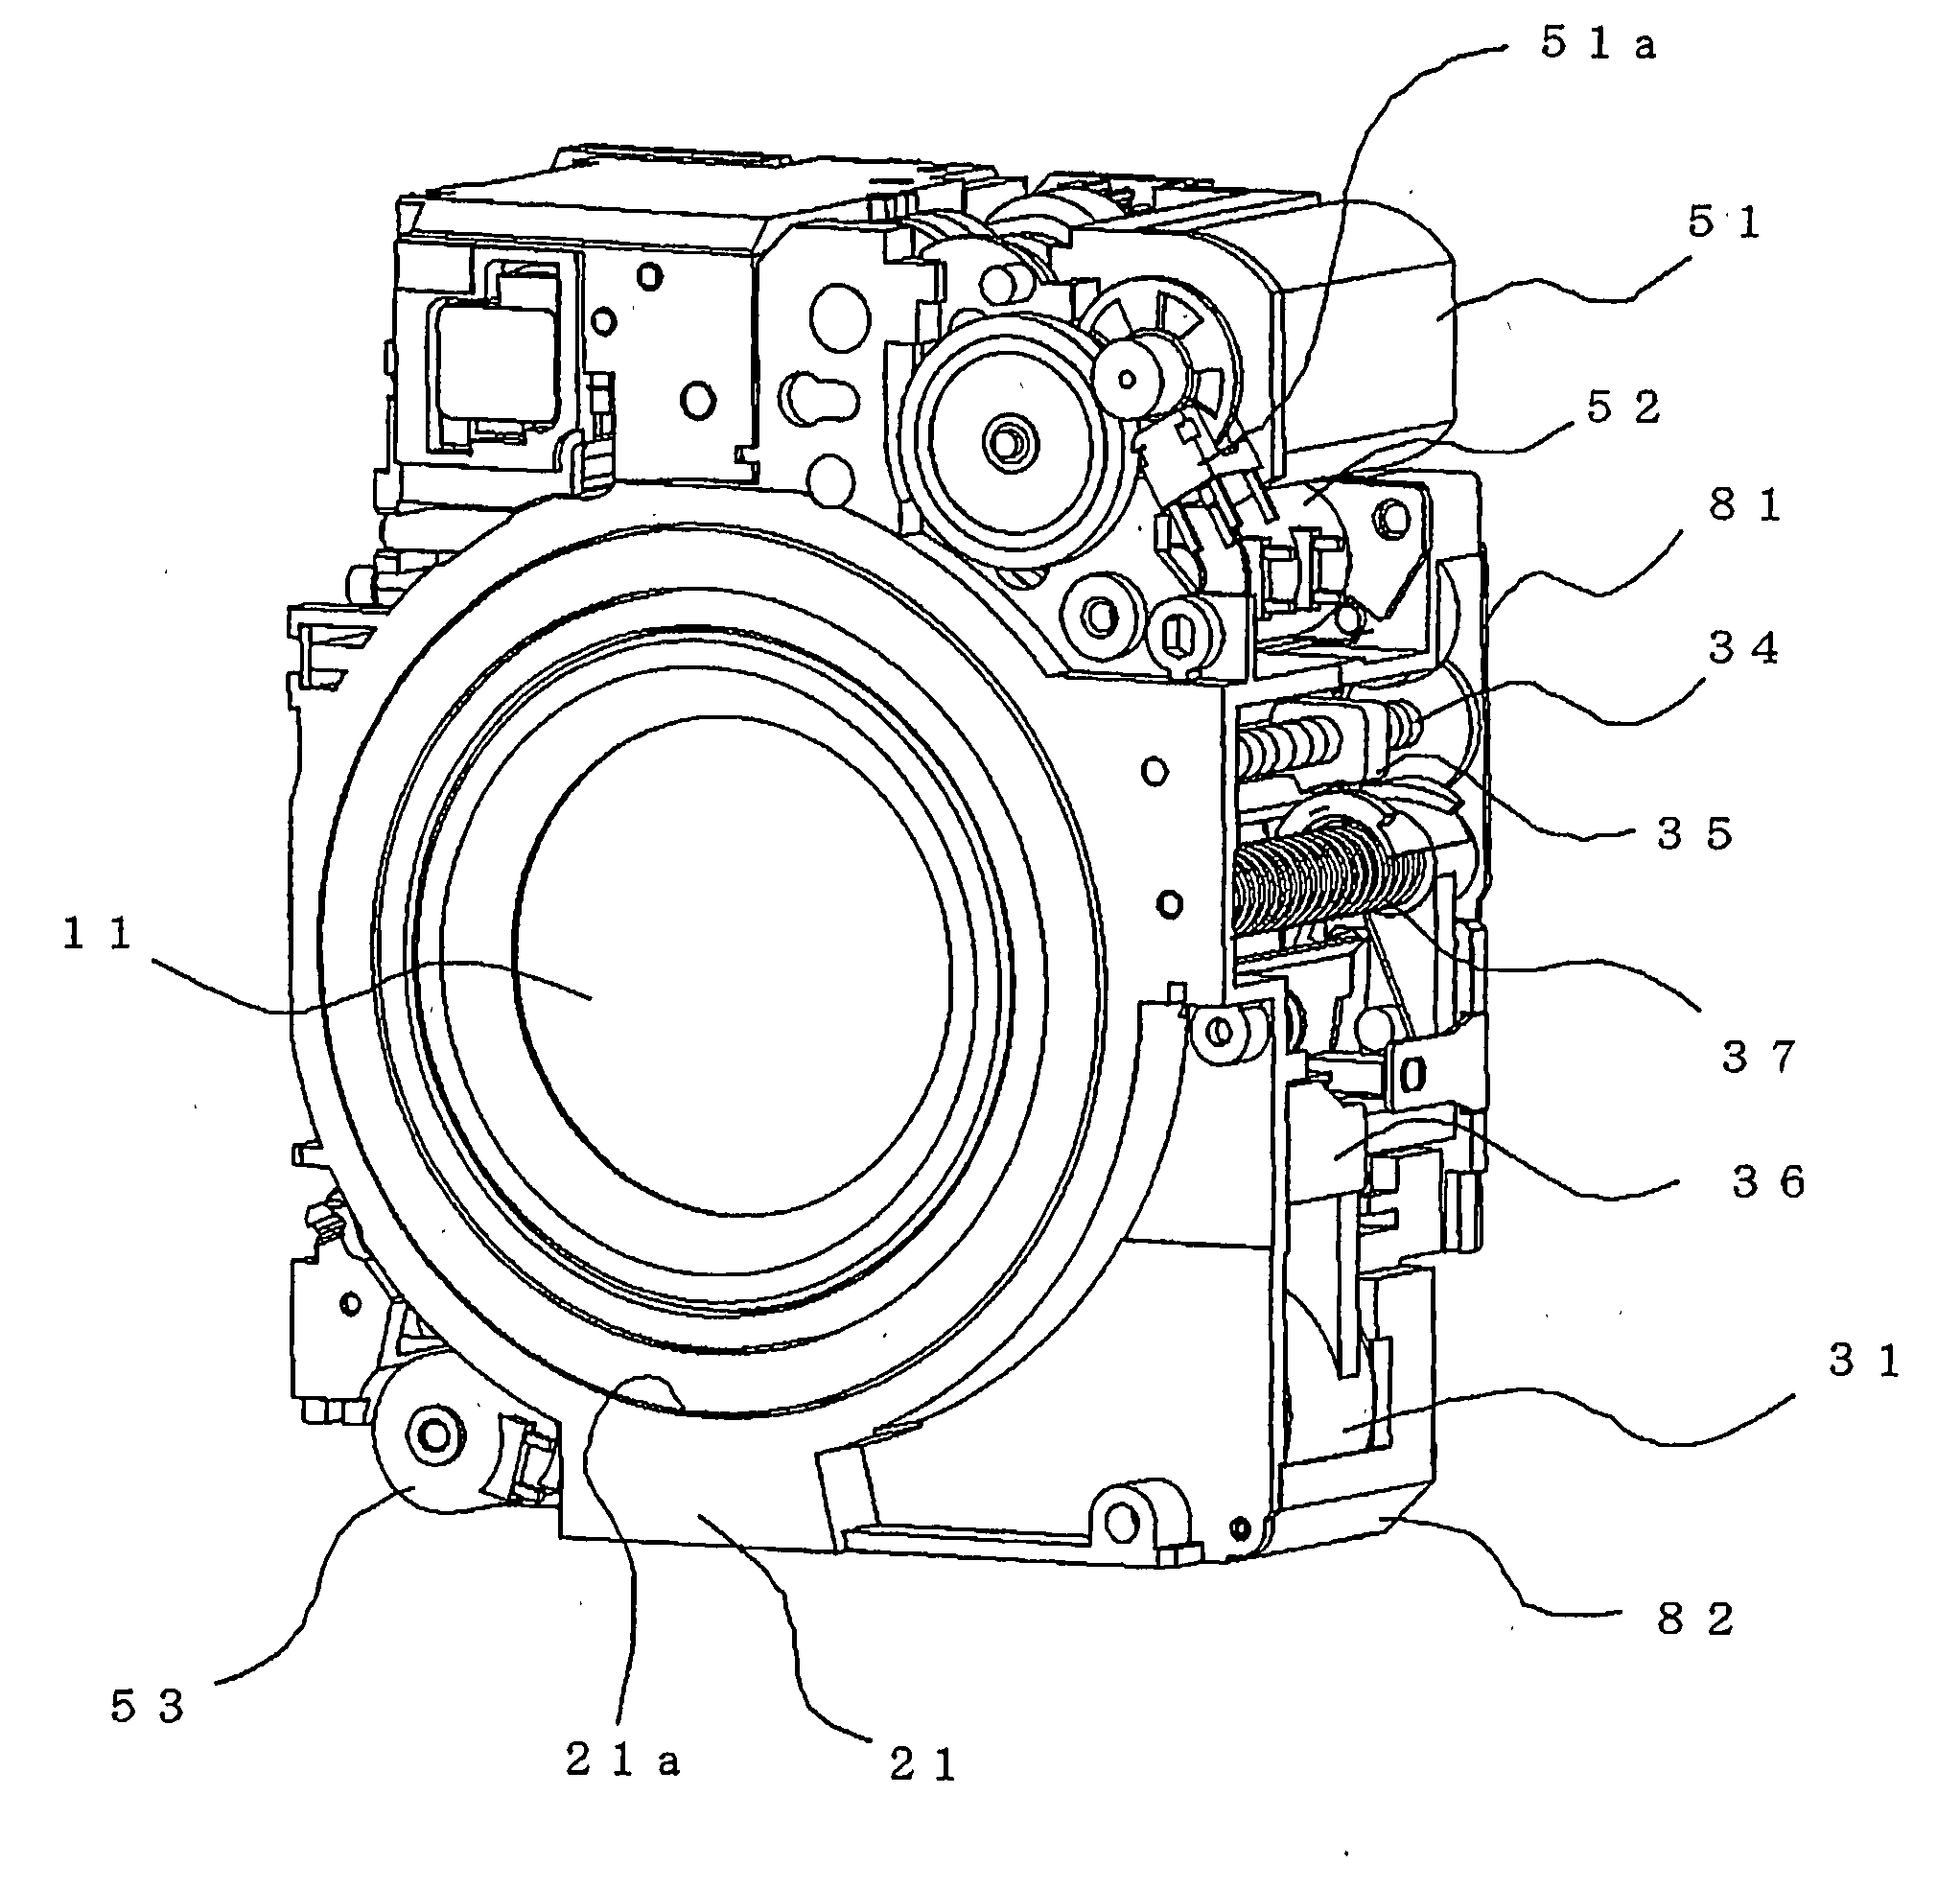
A lens barrel includes: a lens frame retaining at least one portion of the plurality of lens groups; a first lens cylinder supporting the lens frame inside thereof and including a plurality of cam followers on an outer circumferential section thereof; and a second lens cylinder including a mutually parallel plurality of cam grooves in an inner circumferential section thereof and storing the first lens cylinder therein in the collapsed state, the plurality of cam grooves are engaged with the plurality of cam followers and configured to advance and retire the first lens cylinder in a direction of an optical axis by a relative rotation of the first lens cylinder, the plurality of cam grooves have a first cam groove and a second cam groove, the plurality of cam followers have a first cam follower and a second cam follower, the first cam follower and the second cam follower are engaged with the first cam groove and the second cam groove, respectively, and the first cam follower and the second cam follower are disposed in positions mutually different relative to the direction of the optical axis.
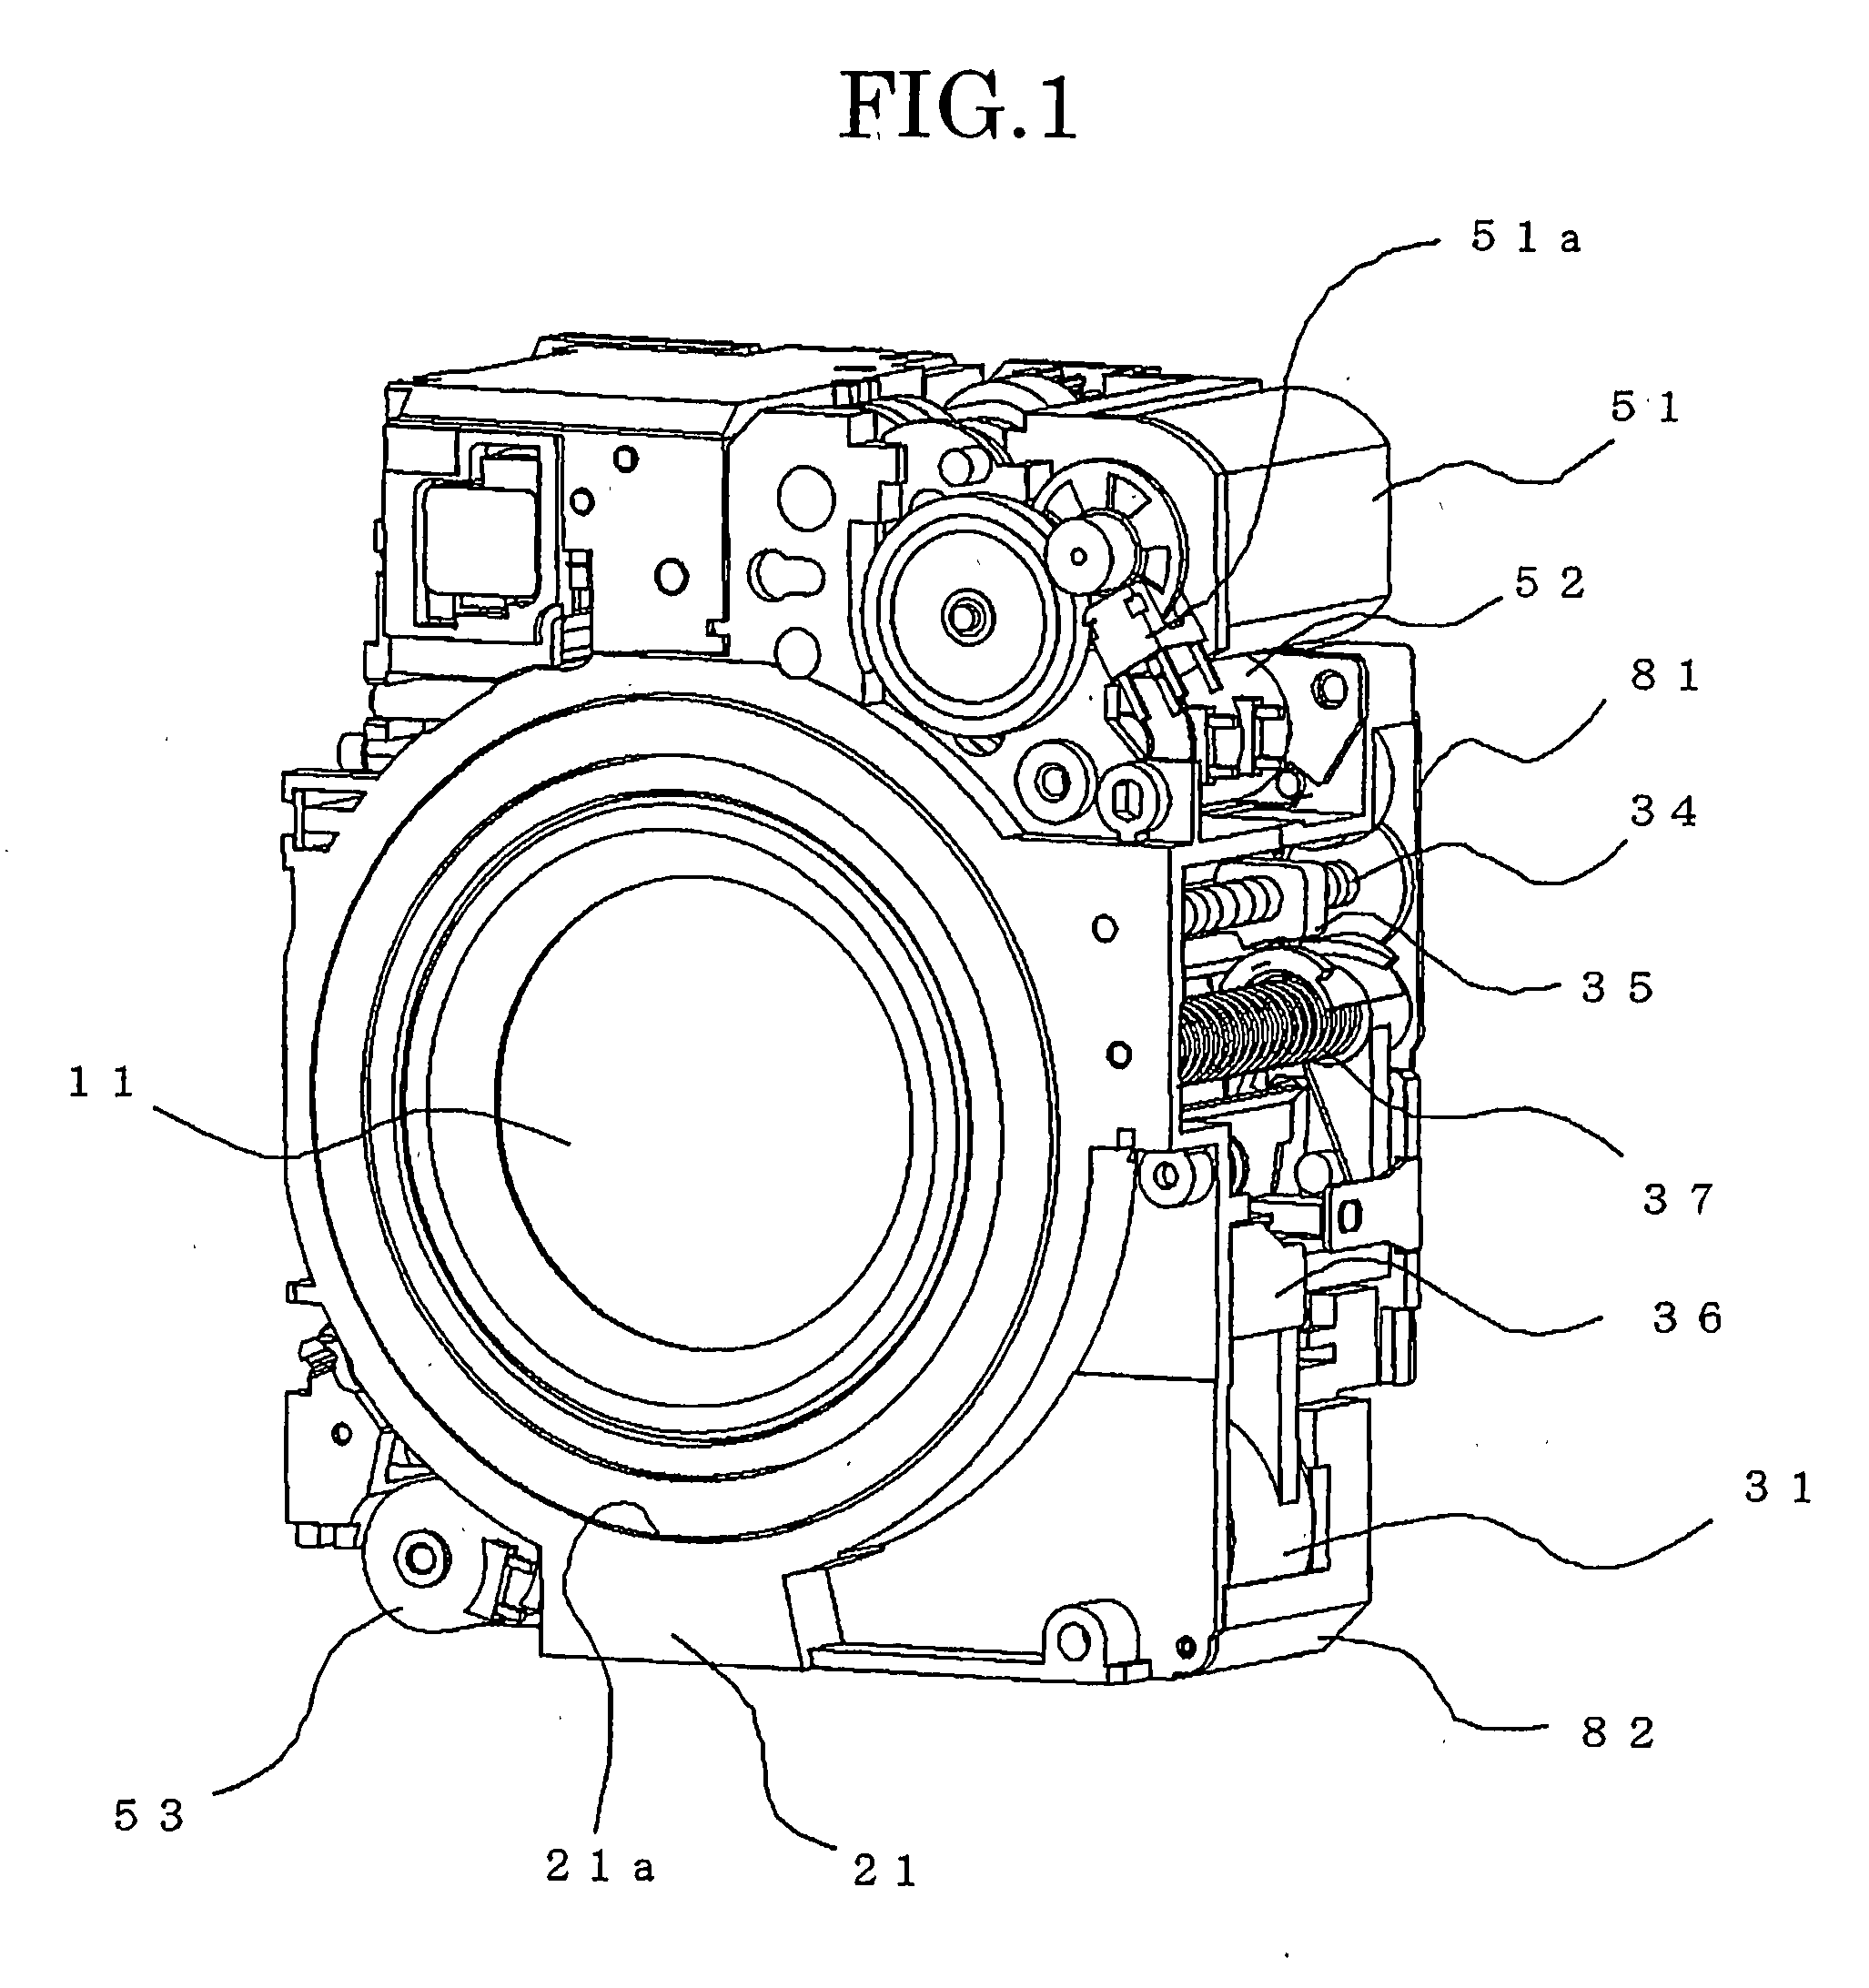
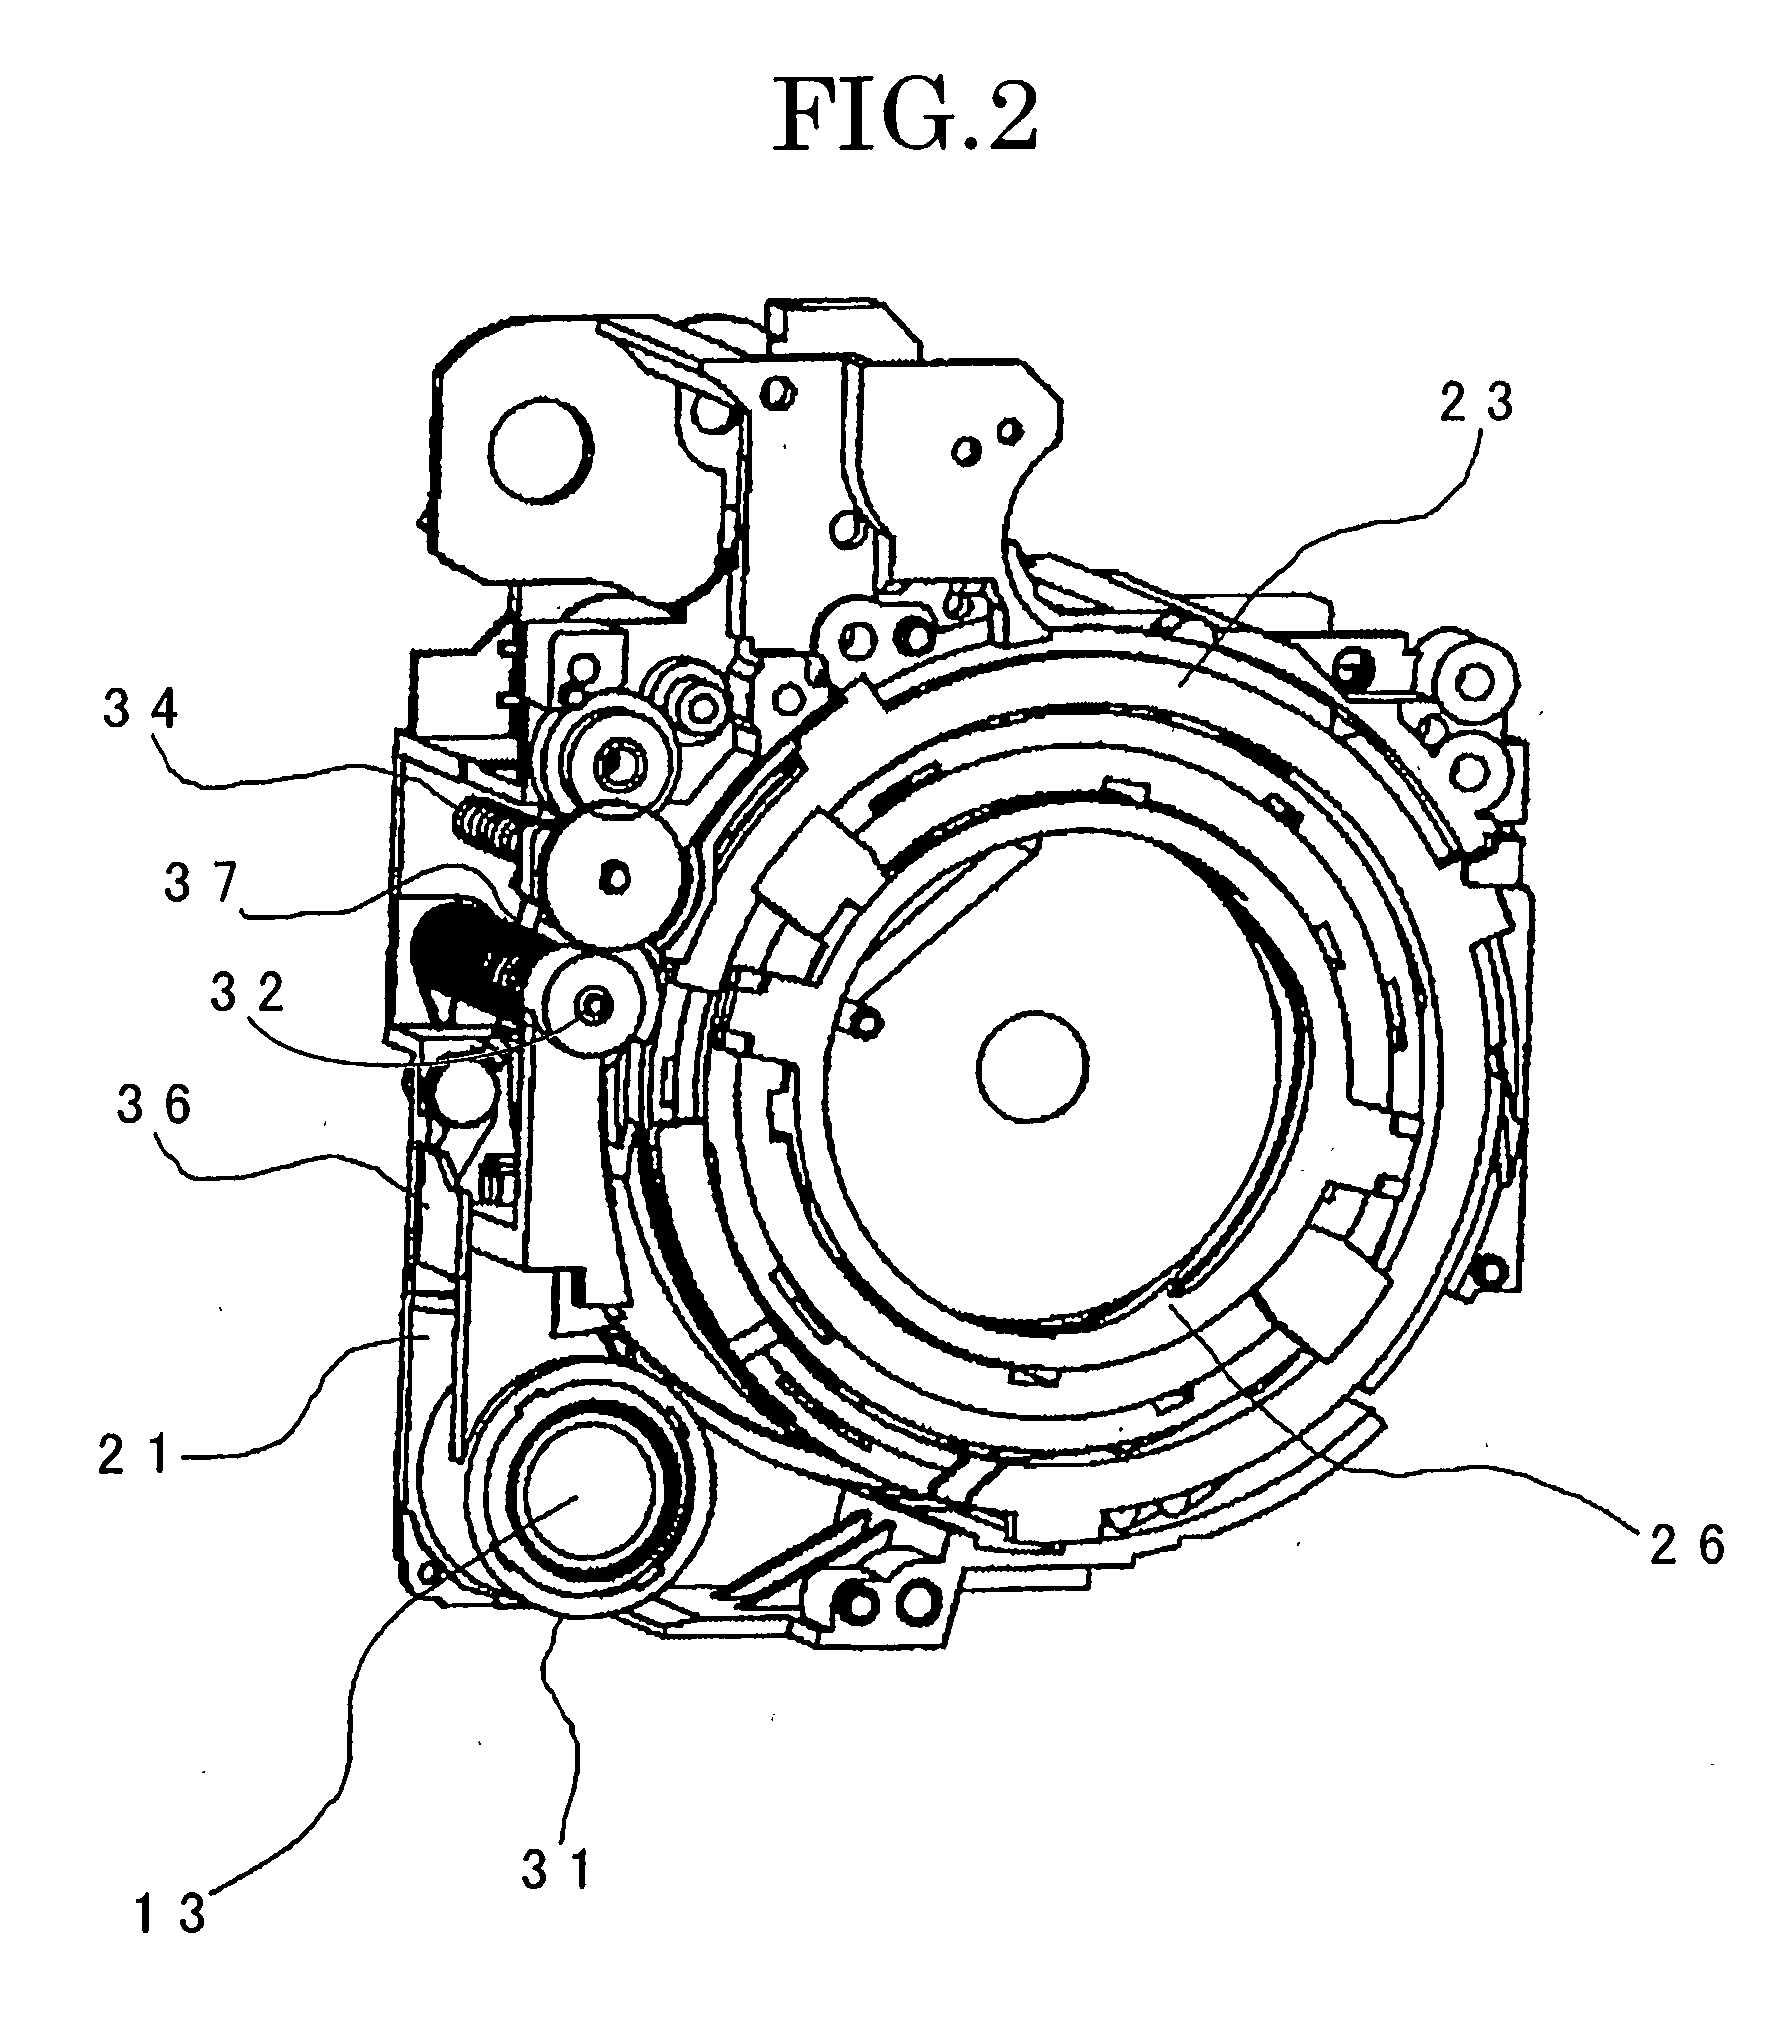
Owner:RICOH KK
Power supply apparatus, power supply system and method of supplying power thereof
ActiveUS20120081088A1Stable drivingMinimal electrical stressBatteries circuit arrangementsEmergency protective circuit arrangementsElectrical batterySunlight
A method of supplying power from a solar cell module to a load includes measuring the output of the solar cell module, and controlling a power converter having a preset duty ratio to start operating in accordance with the measured output. Additionally, a power supply apparatus and a power supply system include a solar cell module having at least one solar cell to absorb sunlight, a power converter which converts power output from the solar cell module and supplies the converted power to a load, and a driving controller which measures the output of the solar cell module and controls the power converter having a preset duty ratio to start operating according to the measured output. Thus, electrical stress on the power converter is significantly decreased even though incident solar energy and / or the load is largely varied, so that the power converter may be stably driven to output the power.


Owner:SAMSUNG ELECTRONICS CO LTD
Electric vehicle and control system and control method for electric vehicle to pass through third rail non-electric interval
ActiveCN106347143AStable drivingPass smoothlyElectric energy managementElectric propulsionReduction rateElectricity
The invention discloses a control method adopted during passing through a third rail non-electric interval. The control method comprises the following steps that the working conditions of a vehicle are obtained; when the vehicle is under the traction or zero-position working condition, a nest step is executed; when the voltage reduction rate of a middle busbar of the vehicle is up to a preset reduction rate, disconnection of a high-speed circuit breaker is controlled; a traction invertor is controlled to disconnect a short-circuit contactor; when it is detected that the voltage of the middle busbar is recovered to reach a normal value, the high-speed circuit breaker is closed. The invention further discloses a control system used during passing through the third rail non-electric interval. In addition, the invention further discloses an electrical vehicle provided with the control system. By the adoption of the control method, the middle busbar of the vehicle is prevented from suffering from larger impact current, and it is effectively ensured that the vehicle smoothly pass through the third rail non-electric interval.
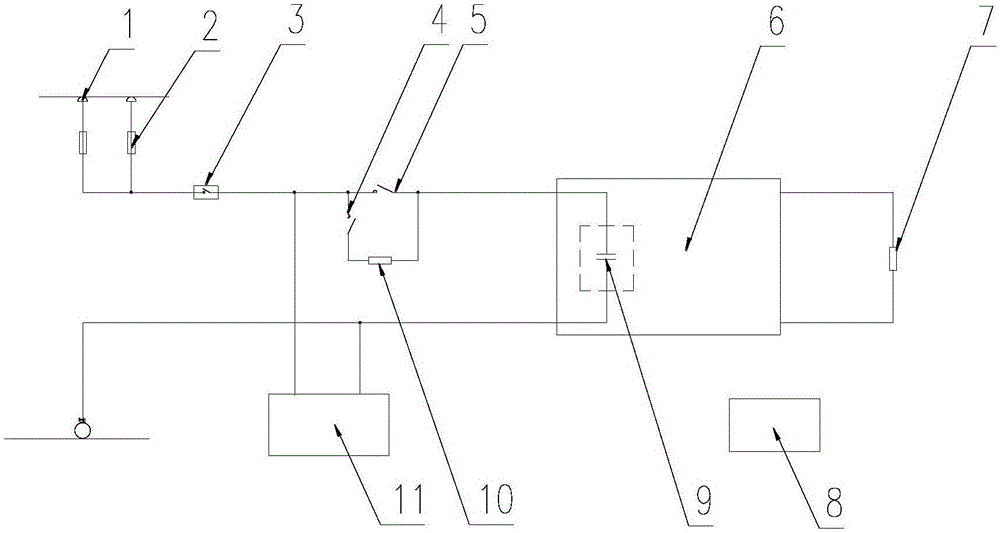
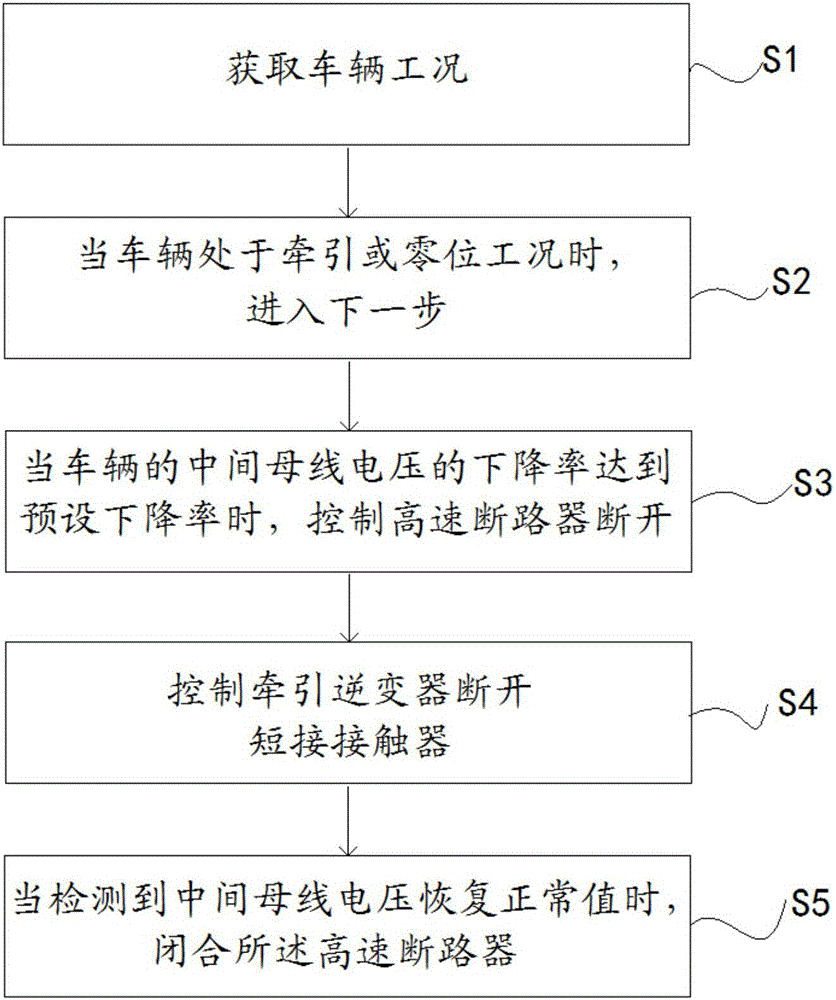
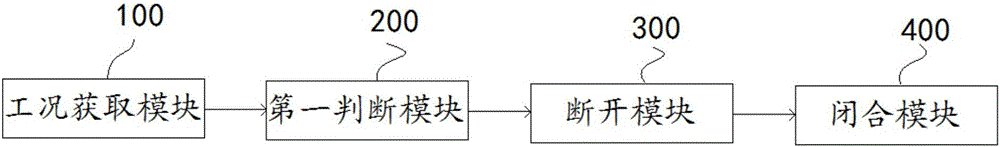
Owner:ZHUZHOU ELECTRIC LOCOMOTIVE CO
LED lighting apparatus and control circuit thereof
ActiveUS20160150607A1Control brightnessStable drivingElectrical apparatusElectroluminescent light sourcesEngineeringElectrical and Electronics engineering
Disclosed are an LED lighting apparatus and a control circuit thereof which controls the brightness of a lamp including LEDs using a dimmer. The LED lighting apparatus and the control circuit use a starting current based on a rectified voltage, in order to supply a holding current to the dimmer in a state where a lamp including LEDs is turned off.
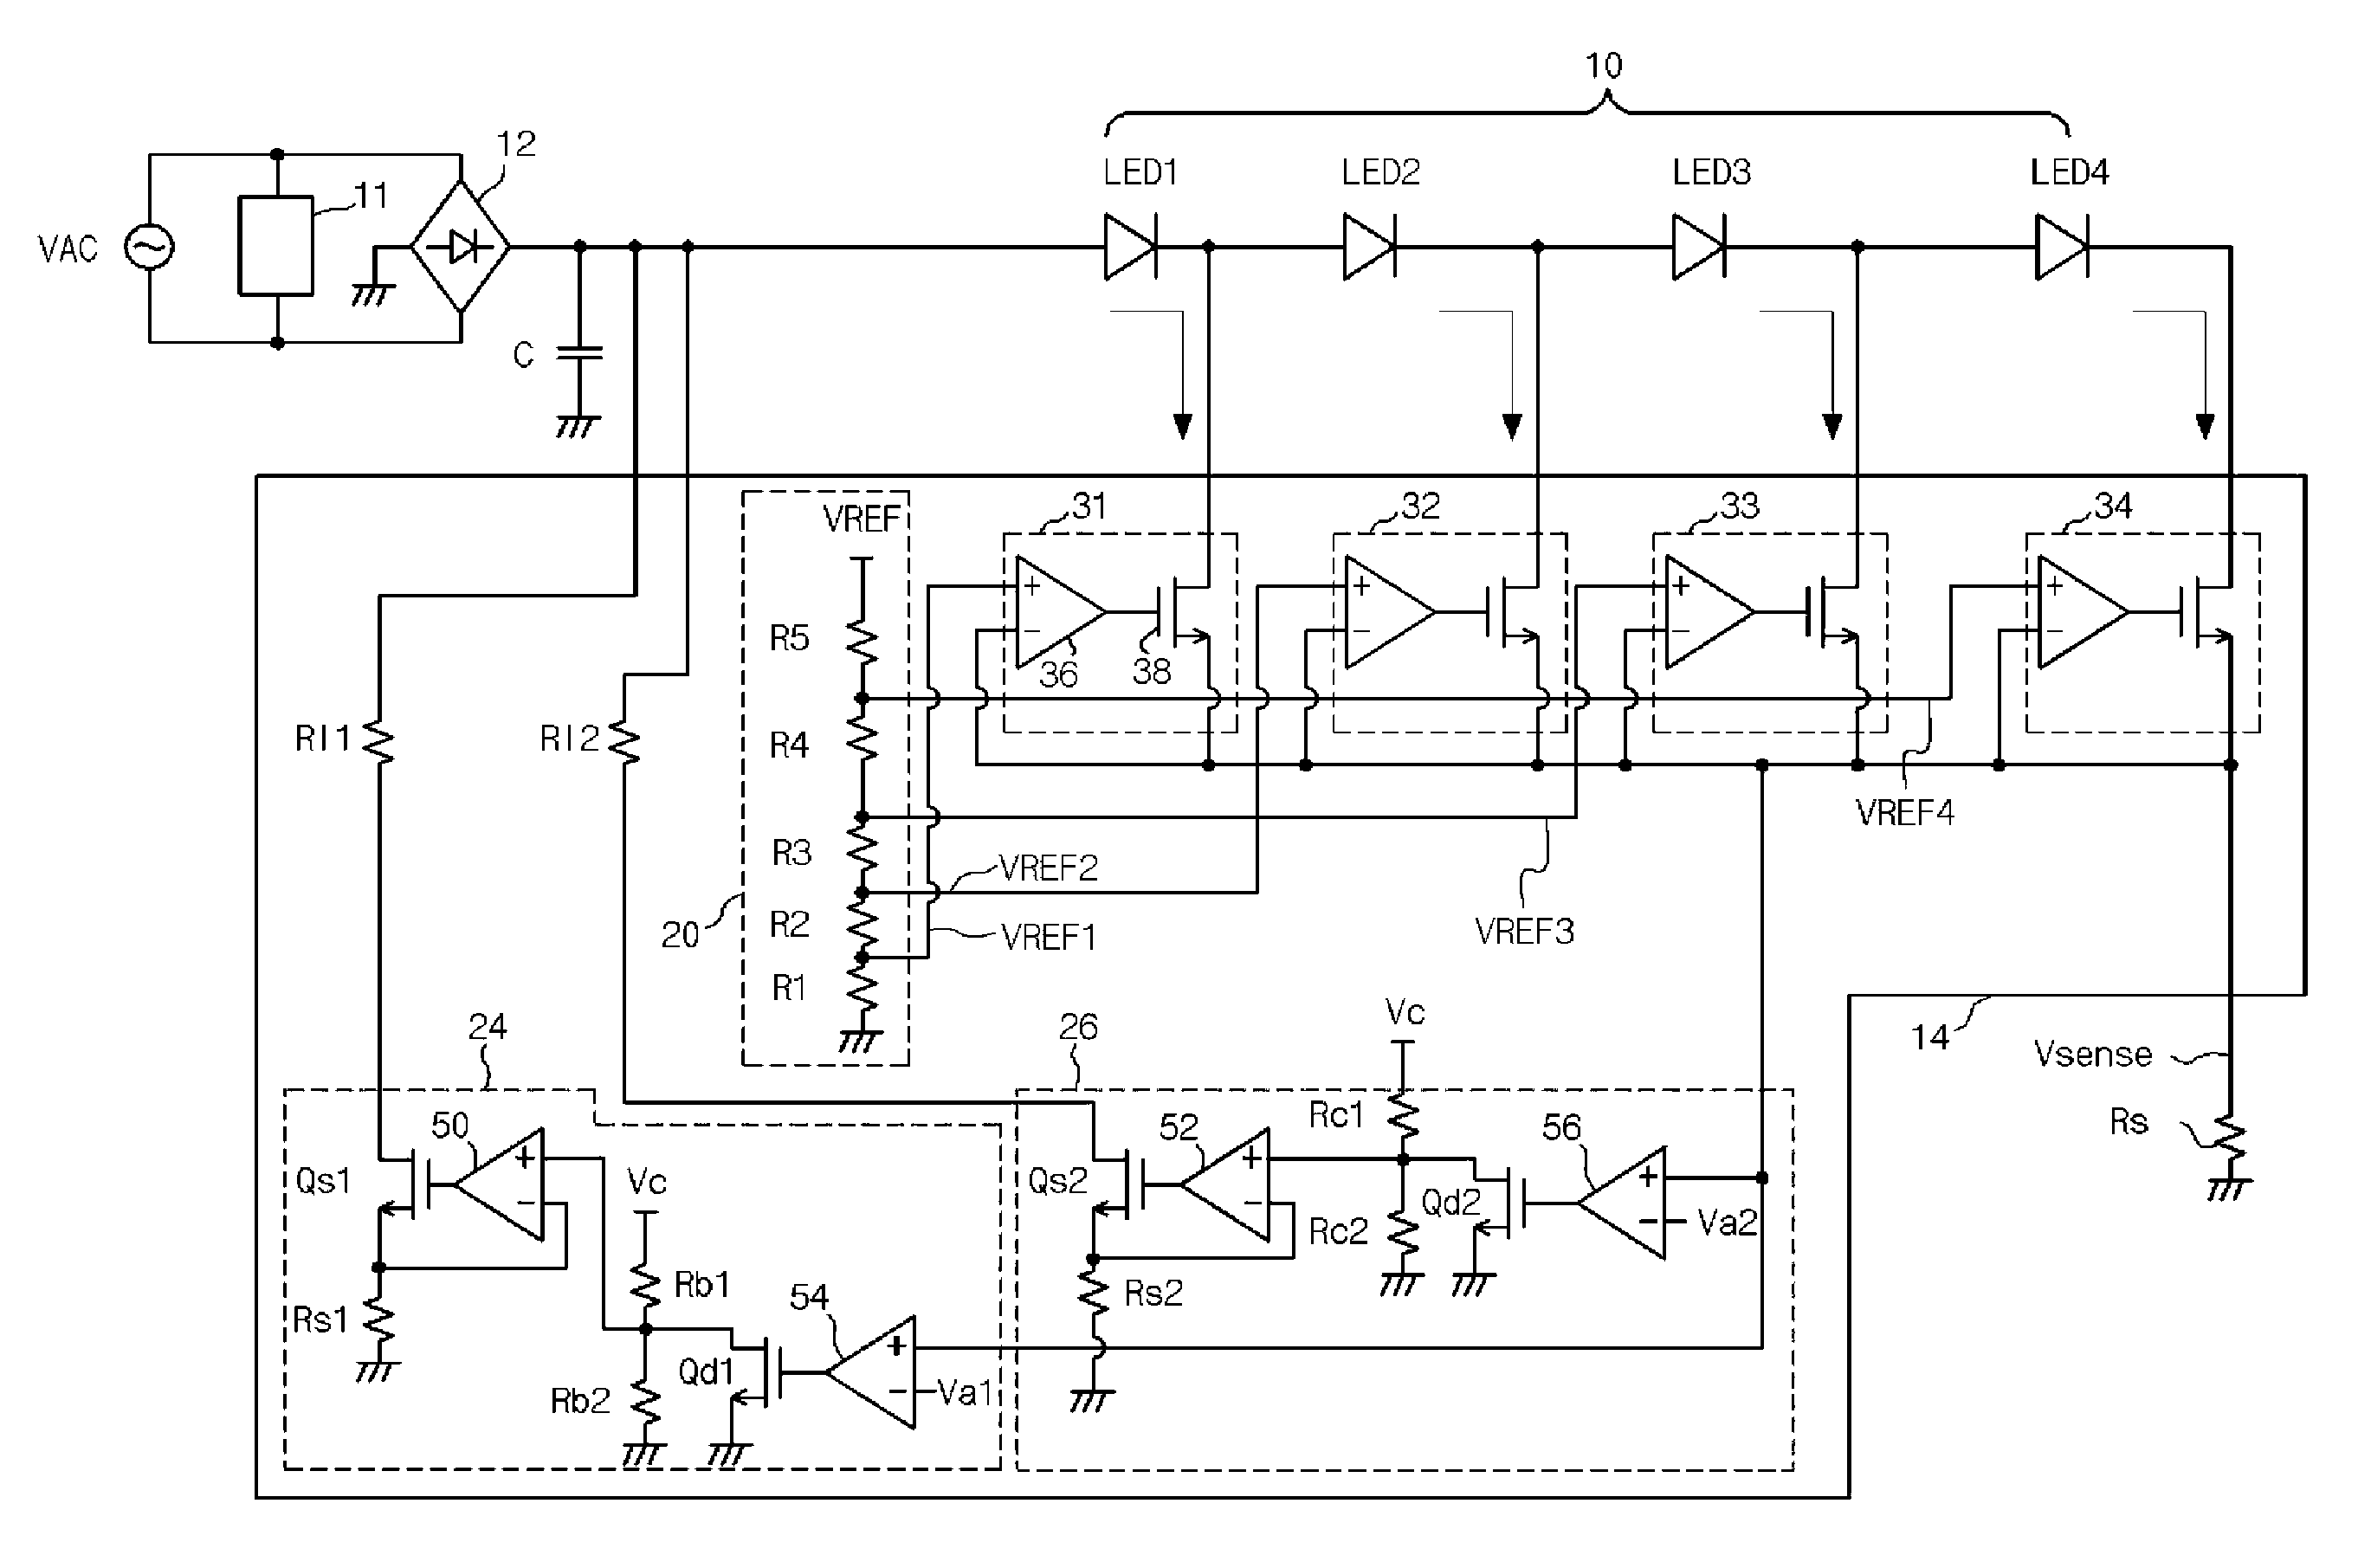
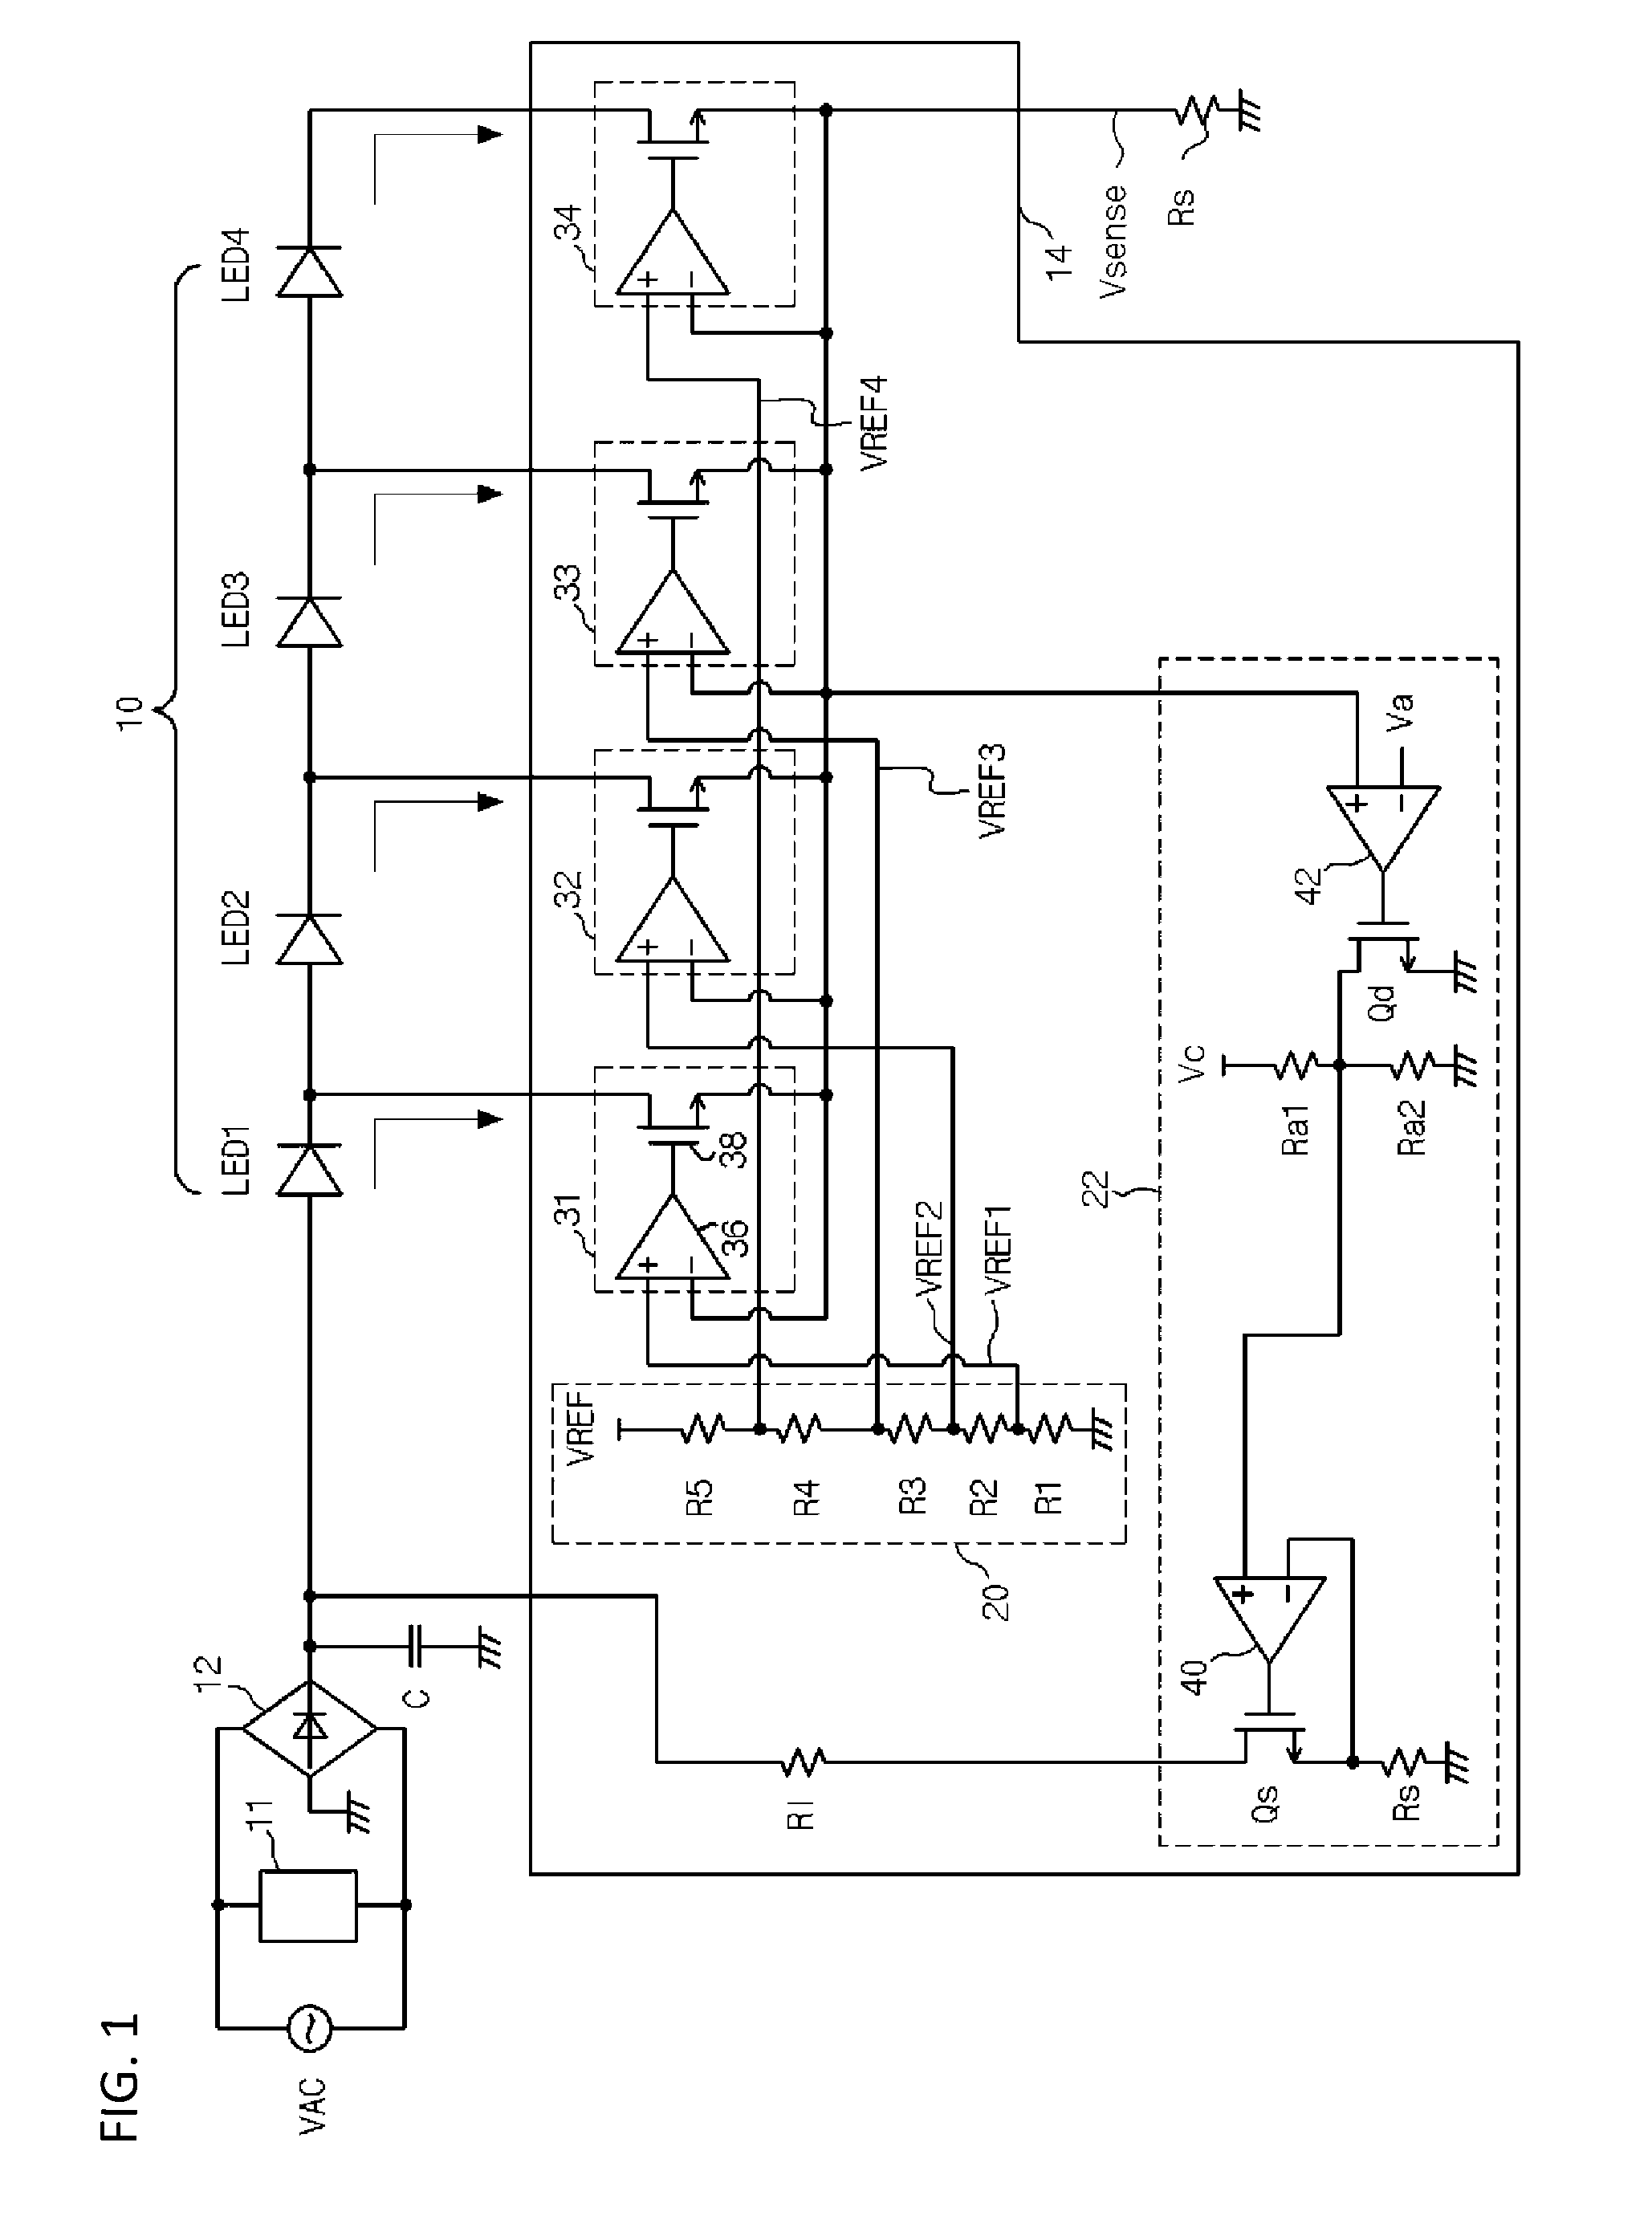
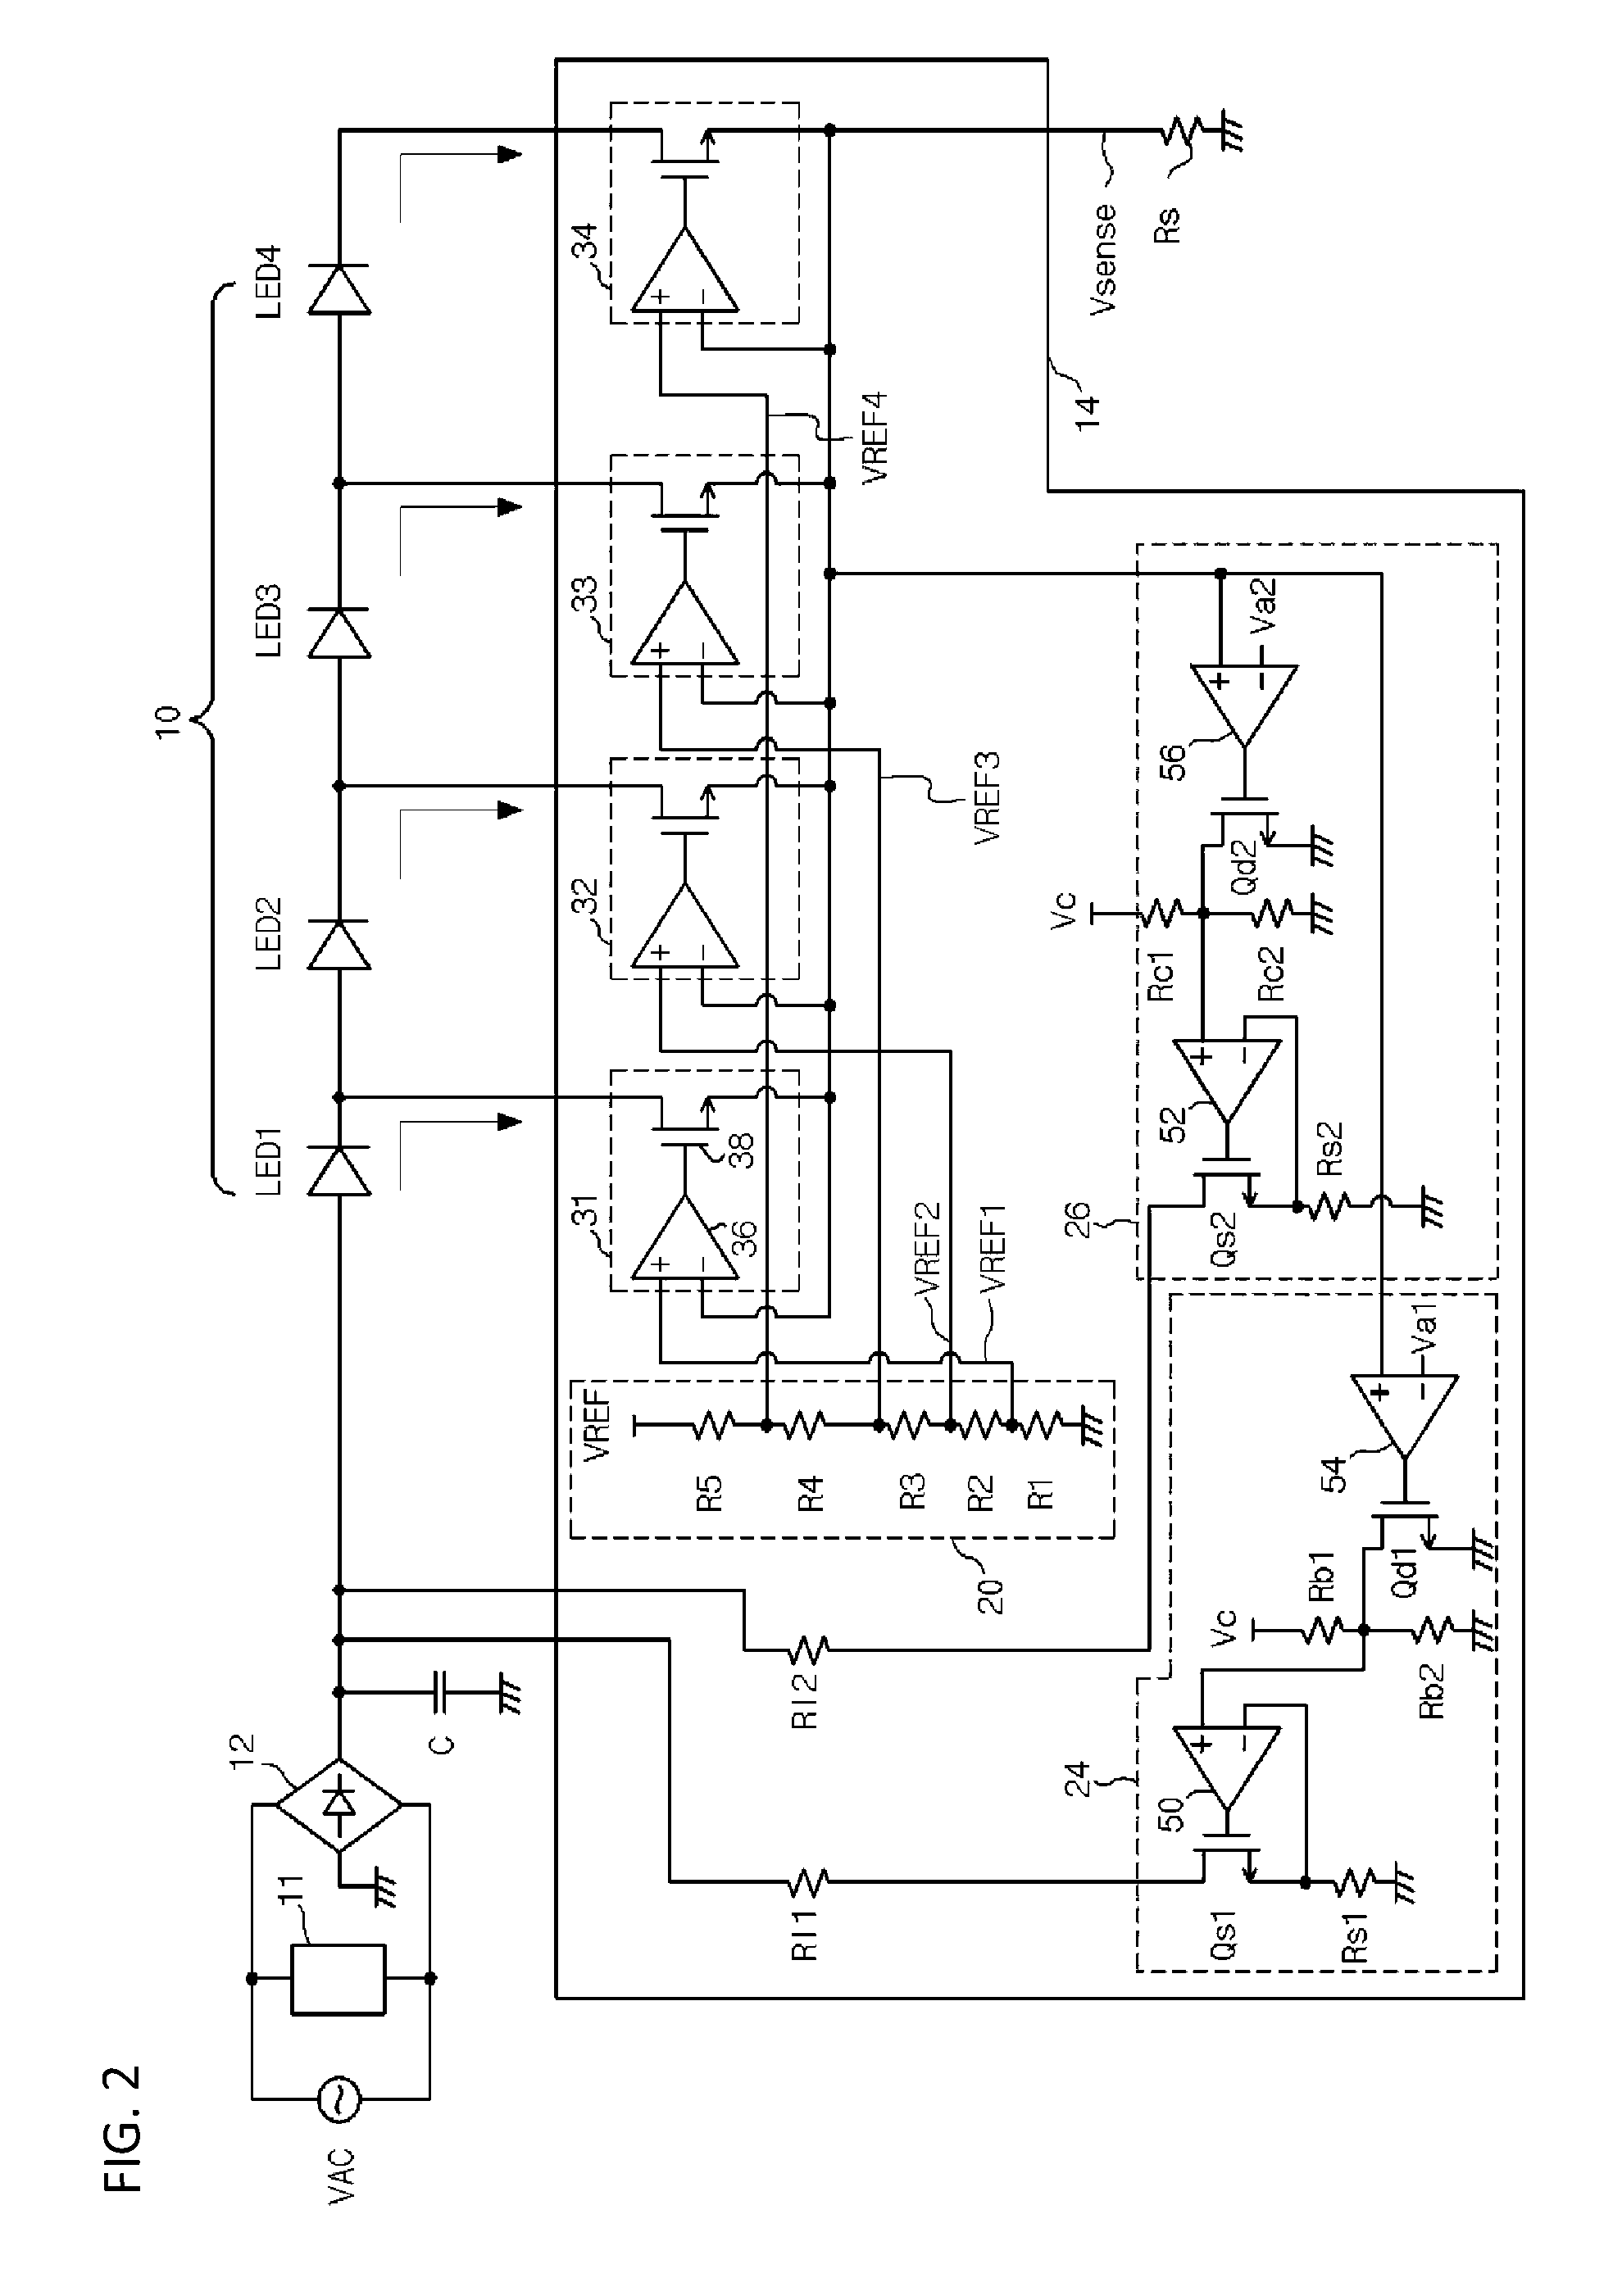
Owner:SILICON WORKS CO LTD
Lamp control device and control method therefor
ActiveUS20180007756A1Stable drivingIncrease aesthetic senseElectrical apparatusElectroluminescent light sourcesVoltageTransverter
A lamp control device may include: a lamp including an LED module having a plurality of LED channels; a converter configured to receive a voltage corresponding to a turn signal, convert the voltage into an output voltage and internal voltage, and supply the output voltage to the LED module; and a controller configured to start counting a preset delay time when the internal voltage is supplied from the converter, and control the plurality of LED channels to sequentially light up at intervals of the delay time.


Owner:SILICON WORKS CO LTD +1
Method for reinforcing riverbank by waste oil, enzymolysis glutinous rice starch and rammed dredger fill
ActiveCN105133572AReduce dosageReduce manufacturing costBreakwatersQuaysFermentationDisposal Technique
The invention relates to a method for reinforcing a riverbank by waste oil, enzymolysis glutinous rice starch and rammed dredger fill, and belongs to the technical field of foundation treatment. The method comprises the following steps: at first, mixed fermentation is conducted on animal oil and prepared compound liquid mold, then glutinous rice which is softened through soaking is cooked, after being automatically cooled, the cooked glutinous rice is mixed with the animal oil and the compound liquid mold and then fermentation is conducted again, and at last, the fermented material is mixed with dredger fill and quick lime to built up a terrace riverbank, and grass and trees are planted on the terrace riverbank. Examples prove that the method is unique and novel, the cement consumption and the cost are reduced, attack of flood or heavy railfall can be blocked effectively, and a truck which is 2-4 t heavy can be stably driven after the riverbank is built up for 2 days.
Owner:浙江丰茂盛业建设有限公司
Motor driving device
ActiveUS20150054435A1Prevent from excessively changeStable drivingCommutation monitoringMotor/generator/converter stoppersAnalog to digital conversionDisconnector
A motor driving device includes an analog to digital conversion circuit to which a speed command voltage instructing a rotation speed of a motor is inputted, and a microcomputer configured and programmed to generate a speed command having a pulse width which is changed according to the speed command voltage based on an output signal of the analog to digital conversion circuit. Further, the motor driving device includes a signal isolator configured to transmit the speed command between an input and an output while providing isolation between the input and the output, and a drive circuit configured to generate a driving signal in response to the speed command outputted from the signal isolator and to change the rotation speed of the motor.


Owner:JAPAN SERVO CO LTD
Control system for wheeled robot to automatically walk along slope center line
ActiveCN111026112AFast convergenceDock stablePosition/course control in two dimensionsControl systemSimulation
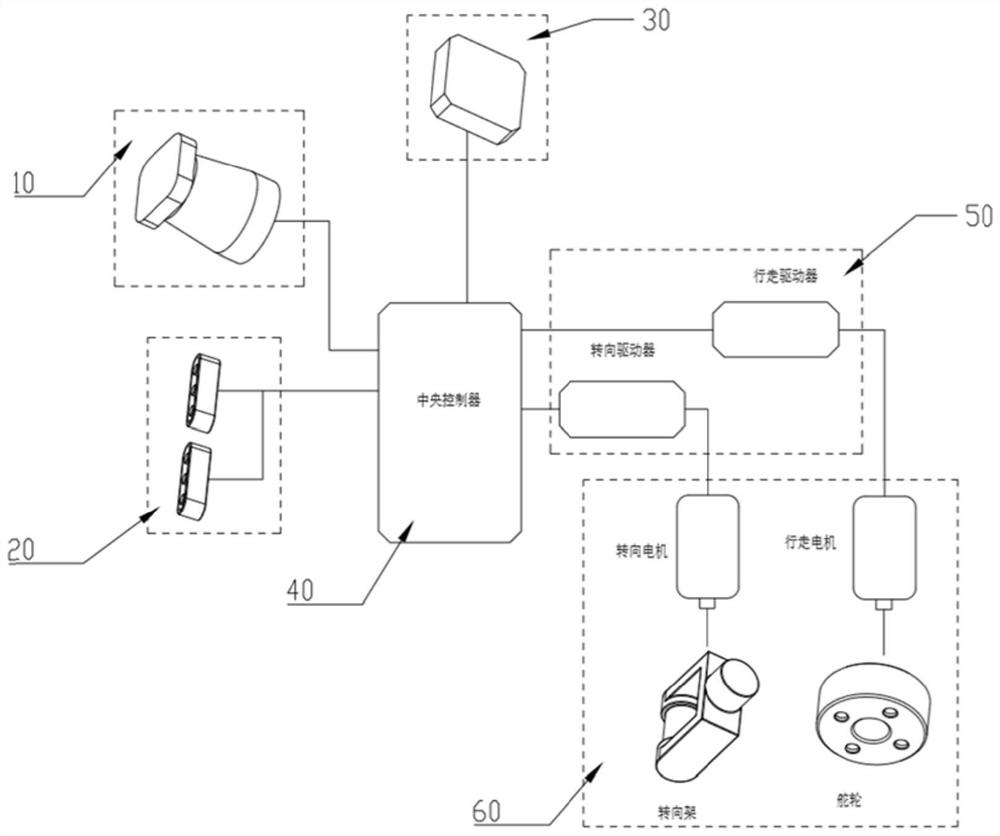
The invention belongs to the related technical field of intelligent control, and discloses a control system for a wheeled robot to automatically walk along a slope center line, which comprises a slopeedge identification module, a target distance identification module, a slope inclination angle identification module, a central controller, a self-adaptive slope inclination angle driving module andthe like. Wherein the slope edge recognition module is used for detecting the slope edge and correspondingly calculating the deviation between the current position of the trolley and the slope centerline, so that the trolley can adjust the self direction to walk along the slope center line; the slope inclination angle recognition module is used for detecting the inclination angle of the robot trolley, and correspondingly, the parameters of the driving module can be configured to enable the trolley to stably run on a slope; and when the trolley approaches the target place, the stop position mark is detected through the target distance identification module, and the trolley can be accurately controlled to realize deceleration parking. By means of the method, effective guarantee can be provided for the wheeled robot to stably crawl along the center line of the slope and accurately stop at a destination.


Owner:HUAZHONG UNIV OF SCI & TECH
Inkjet recording head
ActiveUS7073893B2High speedStable drivingInking apparatusOther printing apparatusElectric fieldRecording head
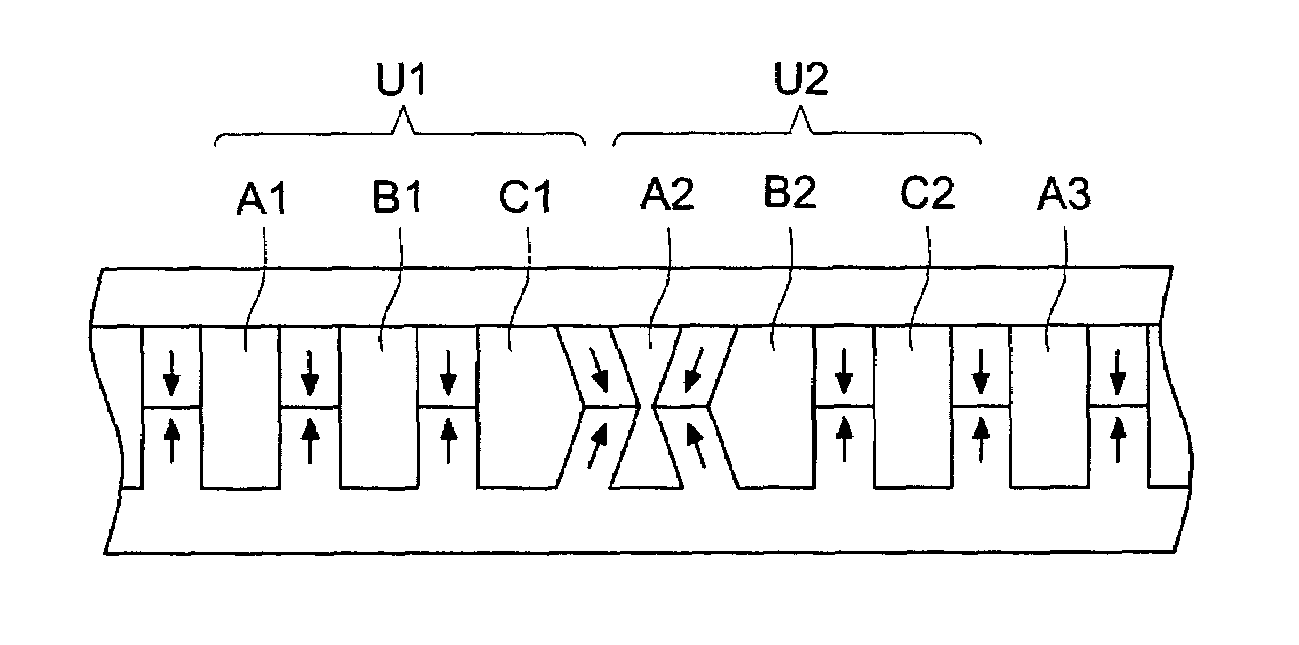
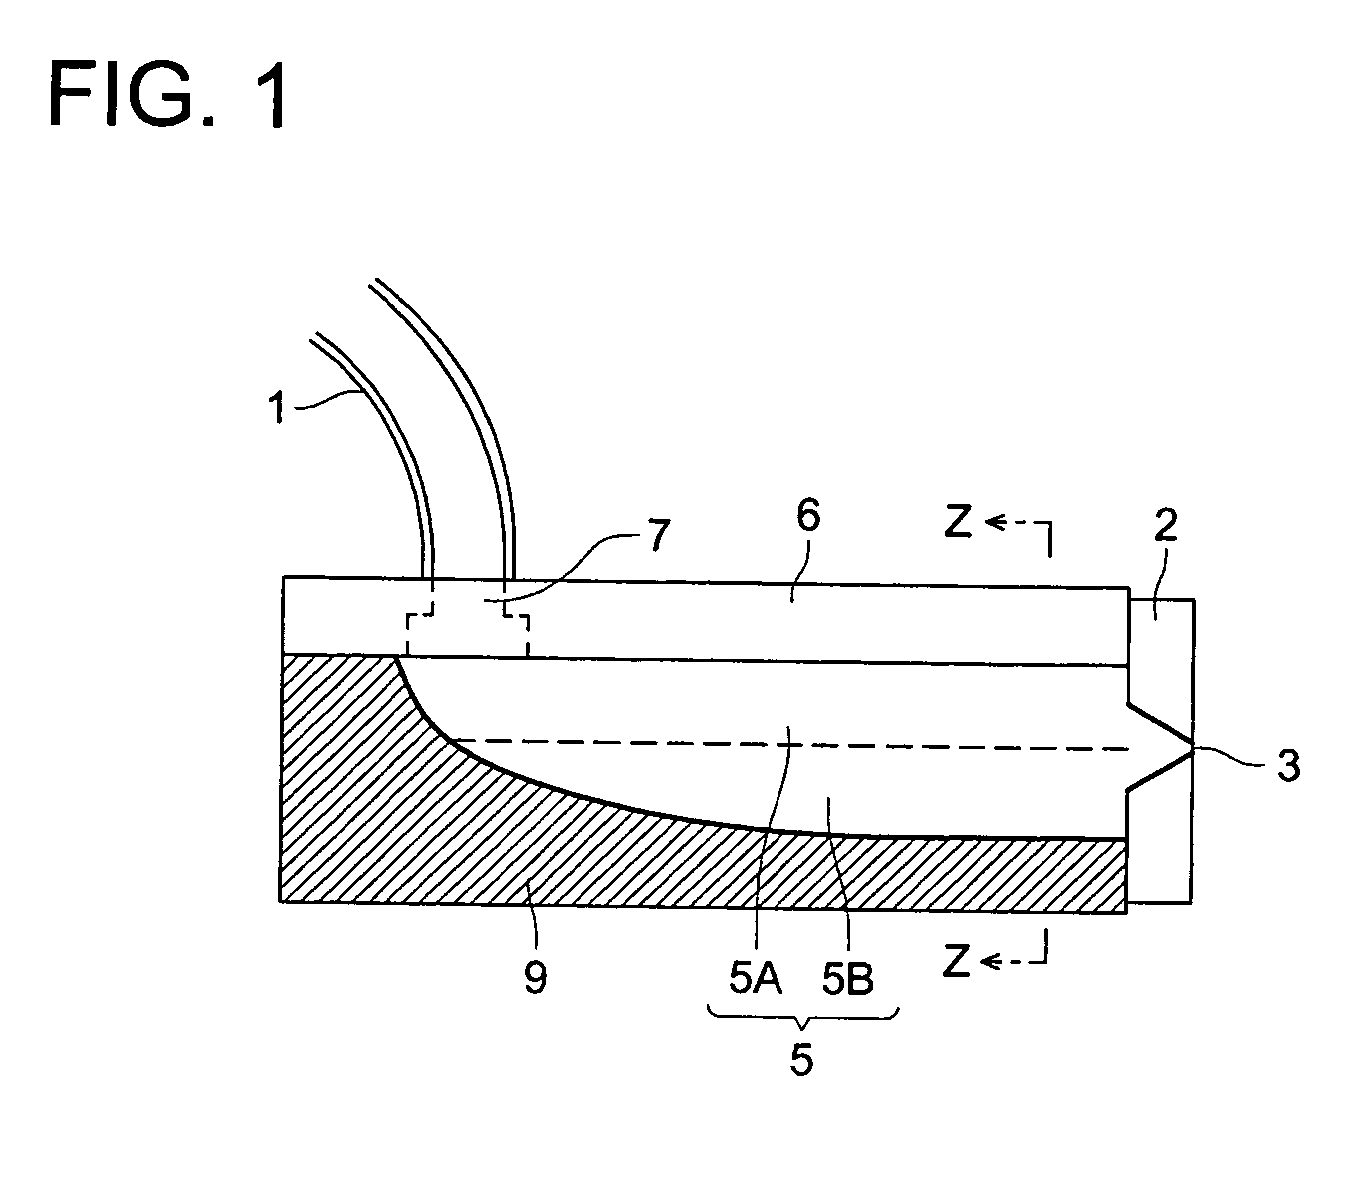
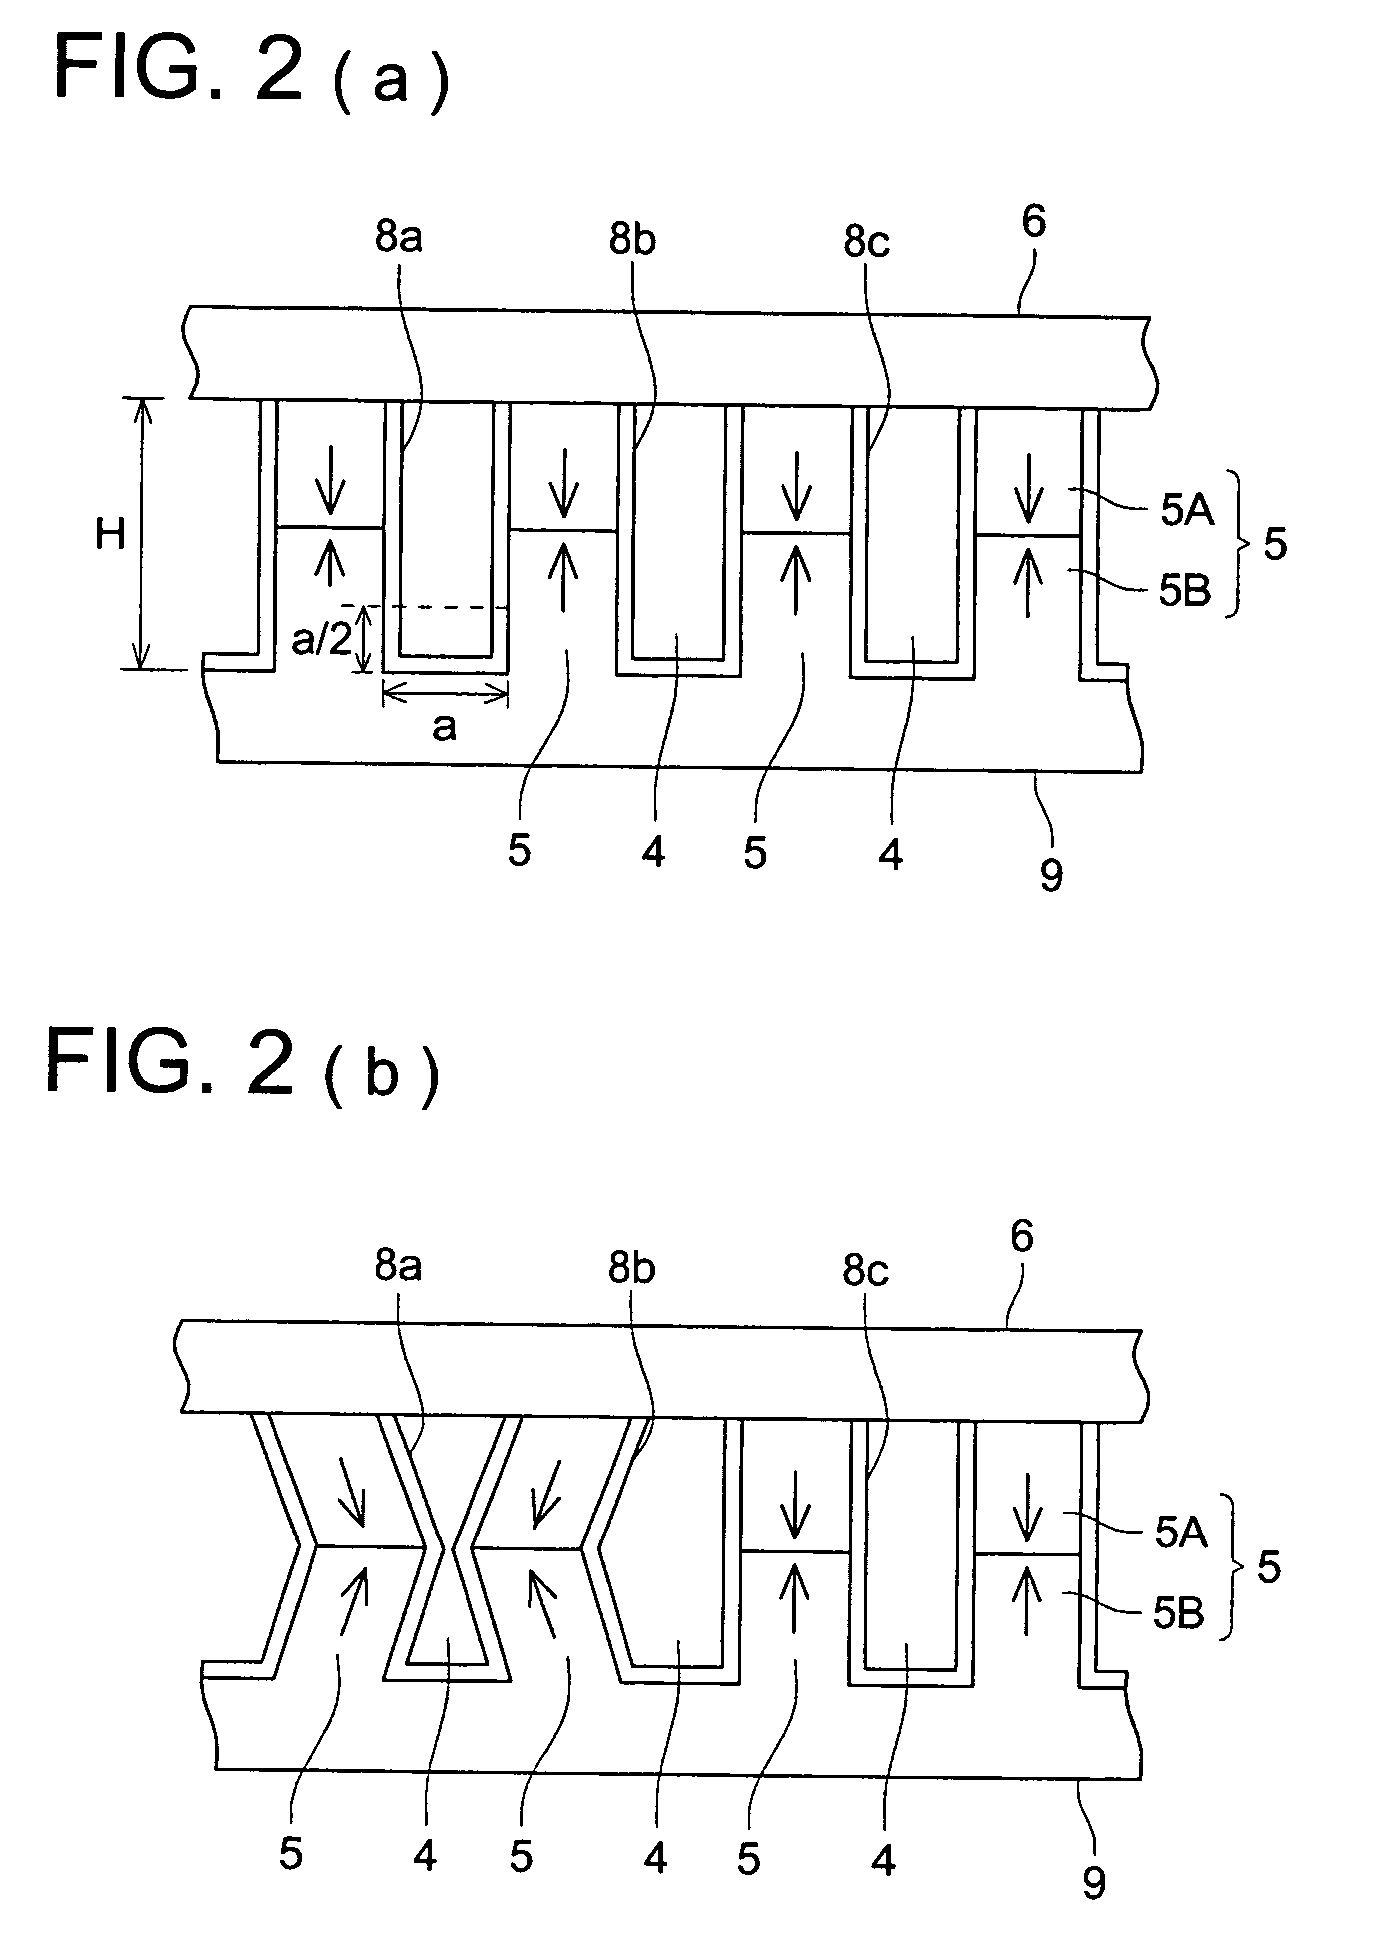
An inkjet recording head for ejecting ink, having a plurality of piezoelectric sidewalls to form a plurality of ink channels; a piezoelectric bottom plate; and a plurality of electrodes All of the ink channels are divided into two or more groups of ink channels composed of ink channels between which at least one ink channel is sandwiched;wherein an ink ejection operation is performed successively in a time-sharing mode for each of the group of ink channels, while satisfying the condition of |CTC+CTE|≦10 (%); where a crosstalk between ink channels in one group due to a compliance ratio of the sidewalls to the ink in the ink channel is CTC; and a crosstalk between ink channels in one group due to a leak of electric field caused by electric voltage applied to the electrodes is CTE.
Owner:KONICA MINOLTA INC
Auxiliary wheel device for motor vehicle
InactiveCN1491815AStable drivingFreedom of movementAuxillary traction increasing equipmentMotor vehicle partEngineering
The auxiliary wheel device for motor vehicle includes support, main shaft, driven mechanism, auxiliary wheel combination and controller. The support has one end pivoted to the bottom of the motor vehicle seat cushion and the other end connected to a raising mechanism; the driven mechanism is connected to the main shaft and the auxiliary wheels; and the controller controls the raising mechanism and the clutch set on the main shaft. When the motor vehicle runs in uneven road, the driver lowers the auxiliary wheels via the controller to contact ground to stable the motor vehicle and increase the safety.


Owner:瑞泰电综股份有限公司
Method of controlling power trunk or power tailgate with synchronization procedure between left and right spindles
ActiveUS20160222713A1Stable drivingIncrease output ratioPower-operated mechanismSuperstructure subunitsEmbedded systemControl system
Disclosed is a method of effectively controlling a vehicle power trunk / tailgate in a vehicle power trunk / tailgate control system by performing a synchronization procedure between the left and right spindles in a vehicle having a power trunk / tailgate. Since a speed difference is not generated between the left and right spindle motors, the power trunk / tailgate can be driven more stably.


Owner:MOTOTECH
Vehicle-mounted health care massage cushion
The invention discloses a vehicle-mounted health care massage cushion and belongs to the field of massage cushions. According to the vehicle-mounted health care massage cushion, physical massaging and medicine health care are combined, a medicine bag in the massage cushion is heated through a heating plate, and then medicine physical therapy is conducted on a user; a plurality of massage devices are arranged on the massage cushion to massage multiple portions of the body at the same time. According to the technical scheme, the vehicle-mounted health care massage cushion comprises a massage pillow, a massage backrest and a massage cushion body, the massage pillow is arranged at the upper end of the massage backrest, the massage cushion body is located at the lower end of the massage backrest, and the massage devices are arranged in the massage pillow, the massage backrest and the massage cushion body respectively; the heating plate is arranged inside the massage backrest, a medicine bag container used for storing the medicine bag is arranged on the portion, corresponding to the heating plate, of the outer surface of the massage backrest, and a sealing strip is arranged on an opening of the medicine bag container. The vehicle-mounted health care massage cushion can be widely applied to the massage cushion field.


Owner:葛新平
Rubber composition for tyre belt layer and tyre prepared from the composition
InactiveCN103172914AExtend your lifeInhibit overheatingSpecial tyresRolling resistance optimizationFiberRolling resistance
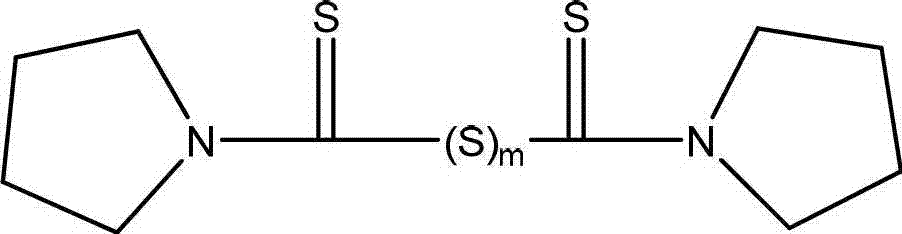
The invention relates to rubber composition for a tyre belt layer and tyres prepared from the composition. The composition includes the components as following: 100 weight parts of natural rubber; and 0.1 to 10 weight parts of aromatic polyamide short fibers processed by the compound shown in the chemical formula 1 or hydrate and polysulfide of the compound. In the chemical formula 1, Me indicats an alkali metal, n is an integer from 1 to 10, and m is an integer from 1 to 6. According to the rubber composition for a tyre belt layer, indurence is guaranteed, simultaneously, over-heating of the belt layer in driving is inhibited, the service of tyres is increased, the rolling resistance is increased, and thereby stable high-speed and long-term driving is guaranteed.
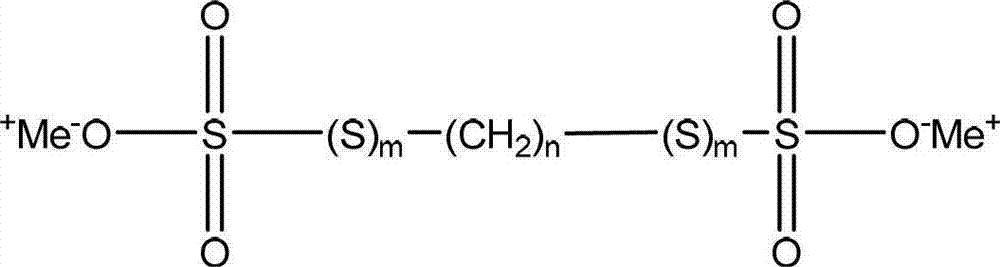

Owner:HANKOOK TIRE WORLDWIDE
Working ignition method of gasification furnace and working glue gas generation system
ActiveCN104152180AWon't burn outExtended service lifeChemical industryCombustible gas productionFlue gasProcess engineering
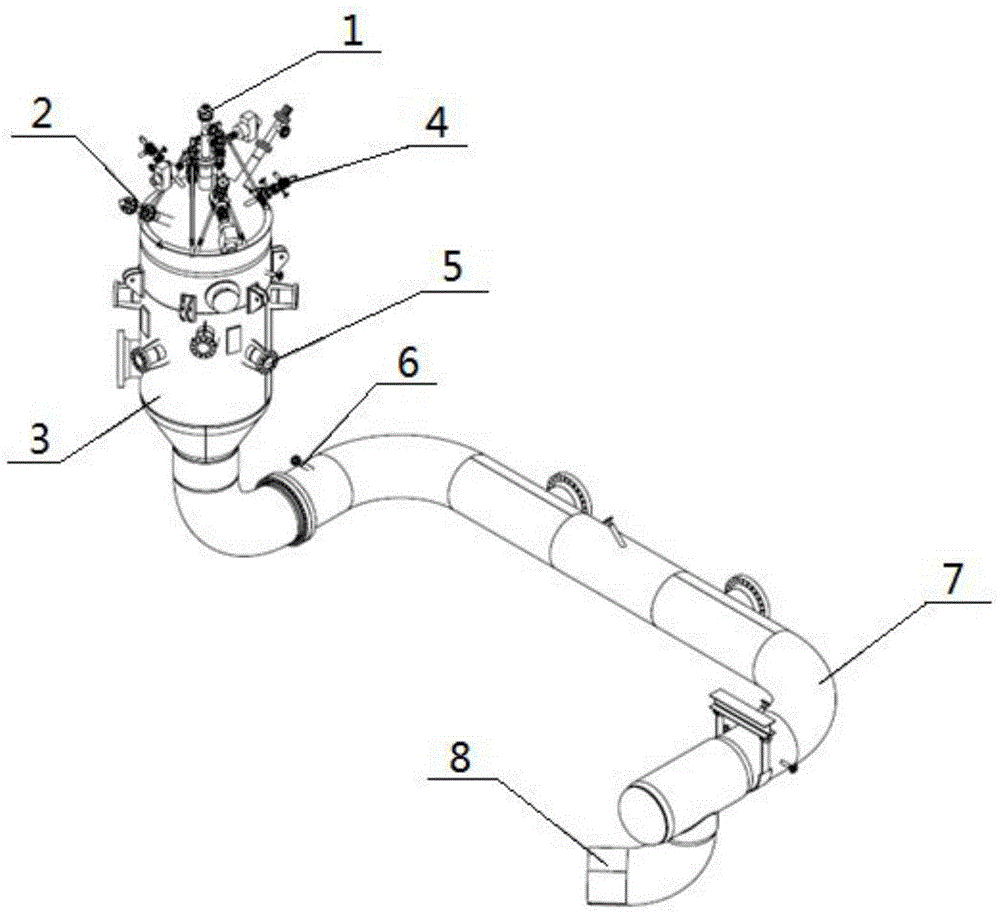
The invention discloses a working ignition method of a gasification furnace and a working glue gas generation system, and belongs to the technical field of chemical energy resources. The working ignition method comprises the following steps: fixedly arranging a burner for working ignition of the gasification furnace on the flue gas generation system outside the gasification furnace, and generating high-temperature flue gas used for working ignition of the gasification furnace through the flue gas generation system; then, conveying the generated high-temperature flue gas to the gasification furnace through a pipeline so as to achieve working ignition of the gasification furnace. The flue gas generation system comprises a flue gas furnace, a flue gas temperature adjusting device used for adjusting the flue gas temperature, a flame detector used for detecting whether a flame is existent in the flue gas furnace or not, a flue used for conveying flue gas, and a fire watching device. The flue gas generation system can provide the flue gas with proper temperature for the gasification furnace, so that the gasification furnace can be stably heated and the heat utilization efficiency of the gasification furnace can reach more than 99%.

Owner:中国船舶集团有限公司第七一一研究所
Control method and system suitable for obstacle avoiding of car
ActiveCN110834628AMaintain driving stabilityStable drivingAutomatic initiationsExternal condition input parametersInformation controlCar driving
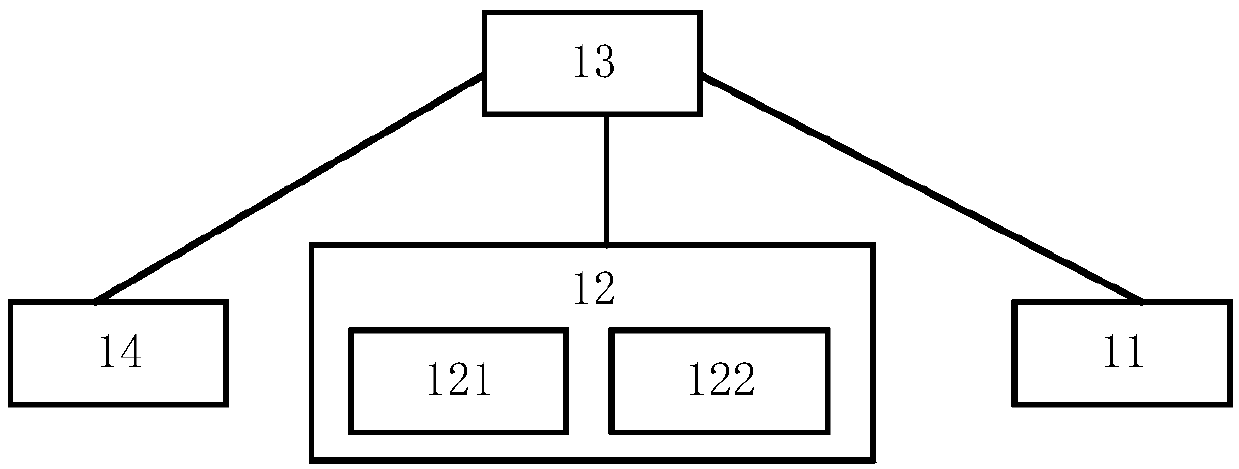
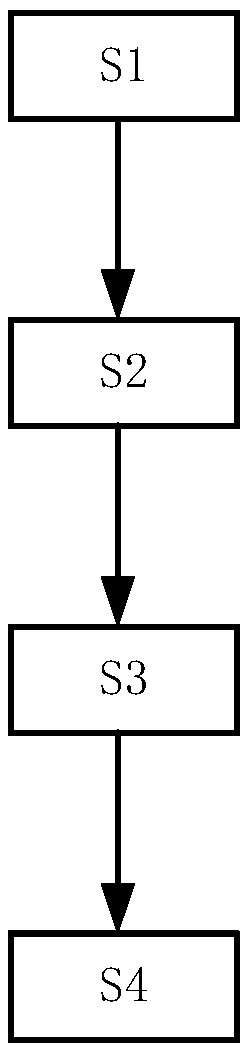
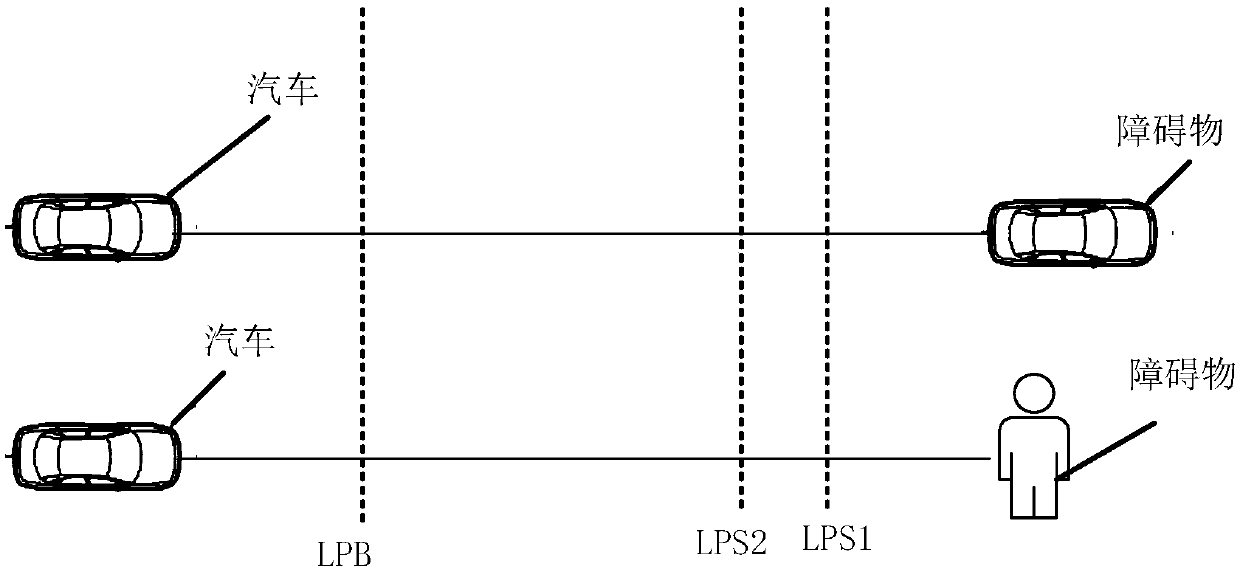
The invention discloses a control method suitable for obstacle avoiding of a car. The method at least comprises the following steps that in a manual driving mode in a car driving mode, on the basis ofa sensor module, car current speed information is obtained; on the basis of an obstacle detection module, obstacle information in front of the car is determined; a control module detects manual operation of a driver for a steering module and a brake module, the control module generates a first steering control instruction and a first brake control instruction on the basis of the manual operationof the driver for the steering module and the brake module, and according to the first steering control instruction and the first brake control instruction, a first control command is generated; a central processor generates a second control command on the basis of the obstacle information and the car current speed information; and in combining with the car current speed information, the obstacleinformation, the first control command, and the second control command, according to the logic mixing manner, a mixed control command is formed, and through the mixed control command, the car is controlled to avoid to obstacles.
Owner:陈勇
Waist-twisting-driven twisting-pushing type sliding plate capable of being played in various ways
PendingCN112316401AGood flexibilityIncrease flexibilityFoldable cyclesSkate-boardsBrakeClassical mechanics
The invention discloses a waist-twisting driven twisting-pushing type sliding plate capable of being played in various ways, which comprises a base plate, bias pressure directional gravity brake-releasing trundles and a force transmission device, a first inclined boss is arranged on the lower bottom face of the narrow end of the base plate, second inclined bosses are symmetrically arranged on thelower bottom face of the wide end of the base plate, and the first inclined boss and the second inclined bosses are distributed in an isosceles triangle shape. A sliding plate handle position is formed in the tail portion of the wide end of the base plate, a first mounting hole is formed in the lower bottom face of the first inclined boss, and a second mounting hole is formed in the lower bottom face of the second inclined boss. The invention relates to the technical field of exercise and fitness tools. According to the invention, the defects of an existing sliding plate are overcome, the sliding plate is driven to slide through waist twisting force, innovative changes are made from the playing form and structure, an operator can control the sliding plate more easily, more safely and morestably, and therefore the market requirements are met.


Owner:GOODMEN HOUSEHOLD PROD TECH (SHENZHEN) CO LTD
Double-channel electrically-controlled electric dimming transmission film with nano wire cluster electrode
ActiveCN105929567AAchieving Dielectric CouplingFine electric transmittance control light operationNon-linear opticsElectricitySpectral domain
The invention discloses a double-channel electrically-controlled electric dimming transmission film with a nano wire cluster electrode. The film comprises a patterned public electrode formed by nano wire clusters closely distributed at a nanoscale interval, a top-surface cathode and a bottom-surface metal nanofilm cathode, wherein the top-surface cathode and the bottom-surface metal nanofilm cathode are distributed at the upper end and the lower end of the patterned public electrode respectively; the top-surface cathode and the patterned public electrode are made of light-transmission films which have nano thicknesses and are made of the same material, and the bottom-surface metal nano film cathode is made of a metal film in a nano thickness; the same optical medium materials in the nano thickness are injected between the top-surface cathode and the patterned public electrode and between the patterned public electrode and the bottom-surface metal nanofilm cathode. Fine electrically-controlled dimming can be performed on transmission behaviors of incident light waves, and the film has the characteristics of applicability to a wide spectral domain and relatively intense light beams, insensitivity to polarization and high dimming response speed.


Owner:HUAZHONG UNIV OF SCI & TECH
A wheeled robot for all-round inspection of underground tunnels and chambers and its control method
ActiveCN113047909BRealize obstacle course activitiesLift restrictionsMining devicesManipulatorMultiple sensorEngineering
The invention discloses a wheeled robot for all-round inspection of underground roadways and chambers and a control method thereof, including a patrol inspection perception system, an external environment monitoring system, a walking obstacle-surpassing system, and a control system; the inspection perception system uses laser radar, Depth cameras, infrared thermal imaging sensors and other sensors use the fusion of multiple sensors such as lidar, depth cameras, and infrared thermal imaging sensors to achieve more reliable inspections; the external environment monitoring system includes sensors such as smoke sensors, sound sensors, and gas sensors to ensure that the robots Safety during inspections; the control system includes the main control box, upper and lower computers and power supplies, and millimeter-wave radar is used for robot driving and obstacle avoidance; the walking obstacle-surpassing mechanism based on the differential balance bar adopts a six-wheel structure to ensure that the robot Between the roadway and the chamber, the variable space can be used to overcome obstacles, which is more stable and reliable. The present invention can be applied to complex environments such as underground roadway chambers to realize advance prediction and early warning of roadway chamber problems.
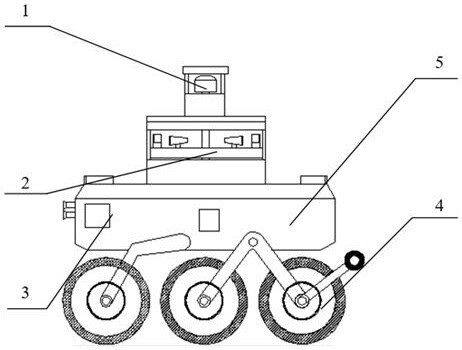
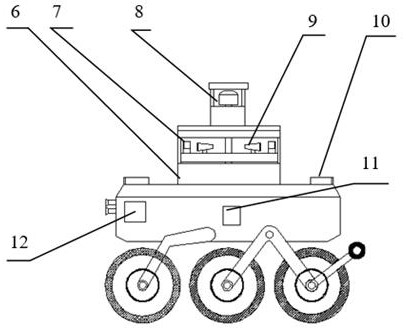
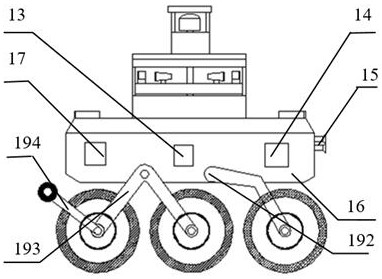
Owner:CHINA UNIV OF MINING & TECH
Method for adjusting brightness of tunnel lamp
InactiveCN106568031AReduce traffic accidentsReduce incidenceMechanical apparatusElectric circuit arrangementsColor mixingElectricity
The invention discloses a method for adjusting the brightness of a tunnel lamp. The tunnel lamp comprises a lamp base and a lamp body, wherein the lamp base is fixed to the wall close to a tunnel entrance, and the lamp body is arranged on the lamp base and connected with electric supply. The method comprises the steps that an illuminance sensor and a master controller are arranged; the lamp body is provided with n sets of LED lamps of different colors, and n is equal to or larger than 2; the illuminance sensor is arranged at the tunnel entrance and used for sensing illuminance data outside a tunnel and transmitting the illuminance data to the master controller; and the master controller adjusts the brightness value of each set of LED lamps according to the illuminance data, and accordingly all the LED lamps can obtain the needed illuminance after color mixing is completed. By the adoption of the method, the brightness of the tunnel lamp can be adjusted automatically according to the brightness of light rays outside the tunnel, a driver can rapidly adapt to the change of the brightness when driving into or out of the tunnel, and the occurrence rate of traffic accidents is decreased.
Owner:JIANGSU JINMI INTELLIGENT TECH CO LTD
A method of using dredging fill to reinforce river embankments
InactiveCN105200958BImprove reinforcementAvoid attackDamsClay mixing apparatusVegetationOrganic matter
Owner:王银山 +15
Grease composition and rolling bearing
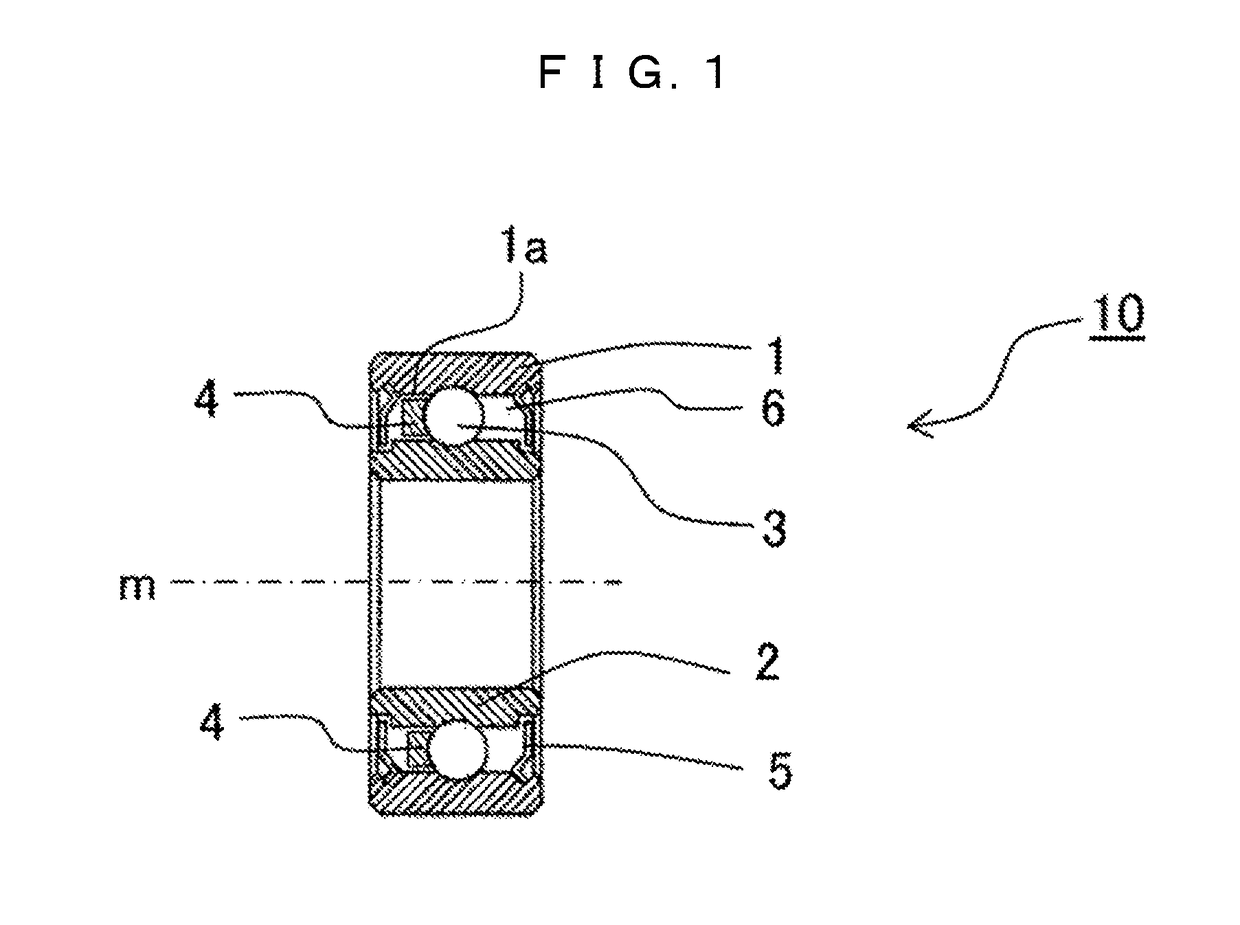
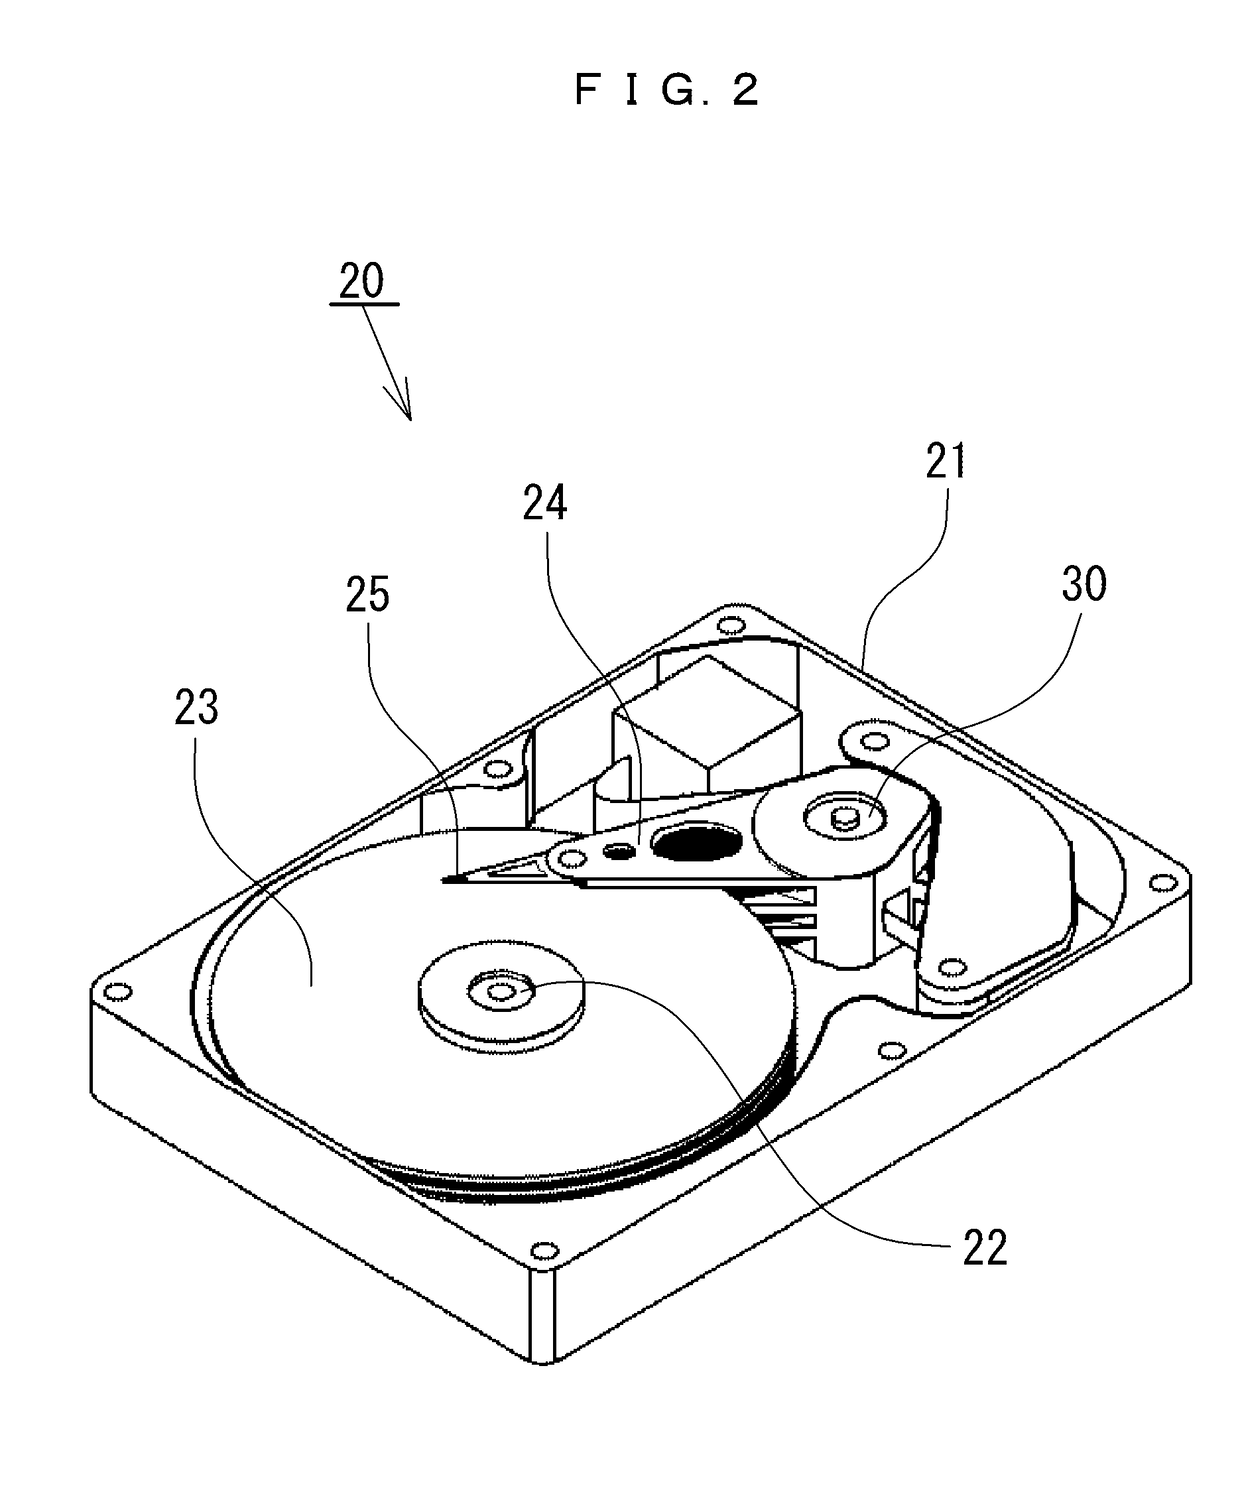
A grease composition includes alkylnaphthalene as base oil and a urea compound as thickening agent. The thickening agent is an alicyclic aliphatic diurea compound contained at a ratio of 4 mass % to 10 mass % based on the total mass of the grease composition. A pivot assembly bearing device is provided with rolling bearings filled with the above grease composition. A hard disk drive device is provided with a swing arm which is swingably supported by the pivot assembly bearing device.
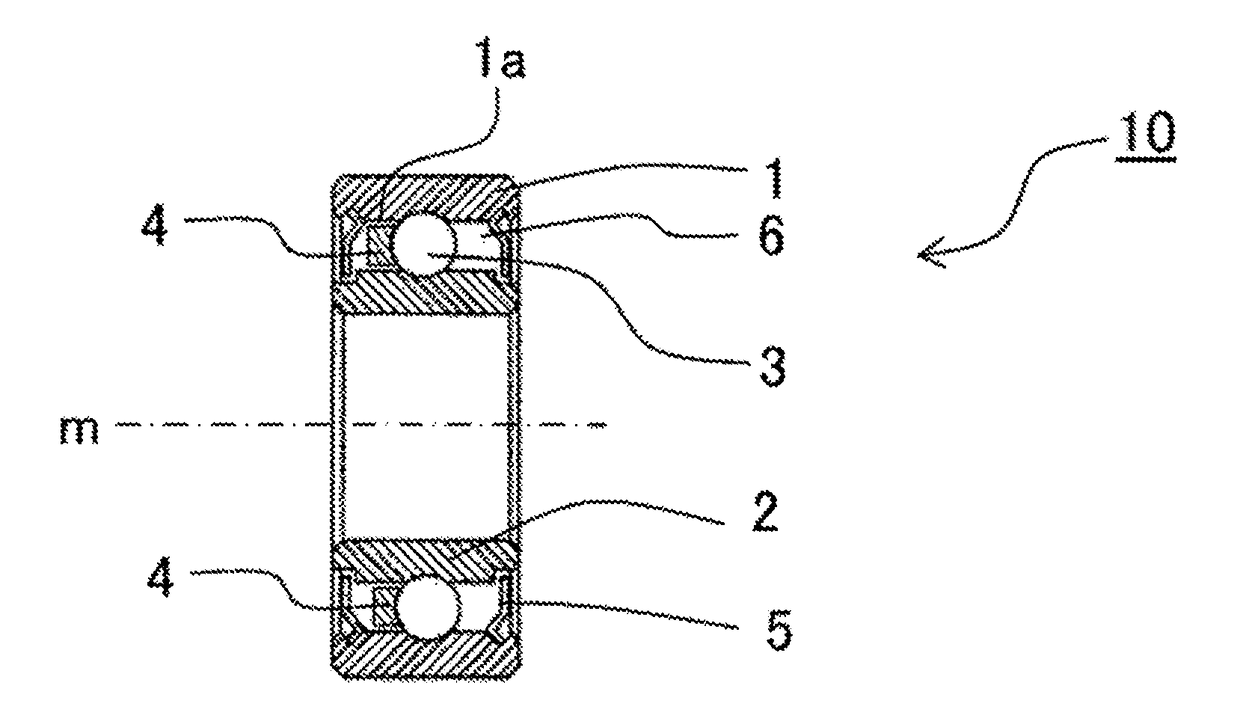
Owner:MINEBEAMITSUMI INC
Watercraft for conveying at least one person on a water surface
InactiveUS20200398939A1Increase flow resistanceStable drivingWater sport boardsMuscle power acting propulsive elementsInput deviceClassical mechanics
The invention relates to a watercraft for transporting at least one person on a water surface, comprising an input device for providing a control instruction, wherein the control instruction depends on an input movement of the person and the input movement can be carried out during travel with the watercraft, furthermore comprising a control device for providing a change and thus a selective increase and decrease of the lift force as a function of the control instruction, furthermore having a transmission device for transmitting the control instruction from the input device to the control device, furthermore having a steering device for providing a change in direction of the watercraft taking place along the water surface as a function of a steering movement by the person, wherein a holding device is provided for enabling a supporting function for the person operating the watercraft, wherein the input movement can be carried out independently of the steering movement and / or the supporting function.


Owner:GRADOLPH CHRISTIAN
An electrically-tunable light-transmitting film with two-way electronically controlled nanowire cluster electrodes
ActiveCN105929567BAchieving Dielectric CouplingFine electric transmittance control light operationNon-linear opticsElectricityNanowire
The invention discloses a double-channel electrically-controlled electric dimming transmission film with a nano wire cluster electrode. The film comprises a patterned public electrode formed by nano wire clusters closely distributed at a nanoscale interval, a top-surface cathode and a bottom-surface metal nanofilm cathode, wherein the top-surface cathode and the bottom-surface metal nanofilm cathode are distributed at the upper end and the lower end of the patterned public electrode respectively; the top-surface cathode and the patterned public electrode are made of light-transmission films which have nano thicknesses and are made of the same material, and the bottom-surface metal nano film cathode is made of a metal film in a nano thickness; the same optical medium materials in the nano thickness are injected between the top-surface cathode and the patterned public electrode and between the patterned public electrode and the bottom-surface metal nanofilm cathode. Fine electrically-controlled dimming can be performed on transmission behaviors of incident light waves, and the film has the characteristics of applicability to a wide spectral domain and relatively intense light beams, insensitivity to polarization and high dimming response speed.


Owner:HUAZHONG UNIV OF SCI & TECH
A gasifier start-up ignition method and start-up flue gas generation system
ActiveCN104152180BWon't burn outExtended service lifeChemical industryCombustible gas productionFlue gasProcess engineering
The invention discloses a working ignition method of a gasification furnace and a working glue gas generation system, and belongs to the technical field of chemical energy resources. The working ignition method comprises the following steps: fixedly arranging a burner for working ignition of the gasification furnace on the flue gas generation system outside the gasification furnace, and generating high-temperature flue gas used for working ignition of the gasification furnace through the flue gas generation system; then, conveying the generated high-temperature flue gas to the gasification furnace through a pipeline so as to achieve working ignition of the gasification furnace. The flue gas generation system comprises a flue gas furnace, a flue gas temperature adjusting device used for adjusting the flue gas temperature, a flame detector used for detecting whether a flame is existent in the flue gas furnace or not, a flue used for conveying flue gas, and a fire watching device. The flue gas generation system can provide the flue gas with proper temperature for the gasification furnace, so that the gasification furnace can be stably heated and the heat utilization efficiency of the gasification furnace can reach more than 99%.
Owner:中国船舶集团有限公司第七一一研究所
A control system for a wheeled robot to automatically walk along the centerline of a slope
ActiveCN111026112BFast convergenceDock stablePosition/course control in two dimensionsControl systemSimulation
The invention belongs to the related technical field of intelligent control, and discloses a control system for a wheeled robot to automatically walk along a slope center line, which comprises a slopeedge identification module, a target distance identification module, a slope inclination angle identification module, a central controller, a self-adaptive slope inclination angle driving module andthe like. Wherein the slope edge recognition module is used for detecting the slope edge and correspondingly calculating the deviation between the current position of the trolley and the slope centerline, so that the trolley can adjust the self direction to walk along the slope center line; the slope inclination angle recognition module is used for detecting the inclination angle of the robot trolley, and correspondingly, the parameters of the driving module can be configured to enable the trolley to stably run on a slope; and when the trolley approaches the target place, the stop position mark is detected through the target distance identification module, and the trolley can be accurately controlled to realize deceleration parking. By means of the method, effective guarantee can be provided for the wheeled robot to stably crawl along the center line of the slope and accurately stop at a destination.
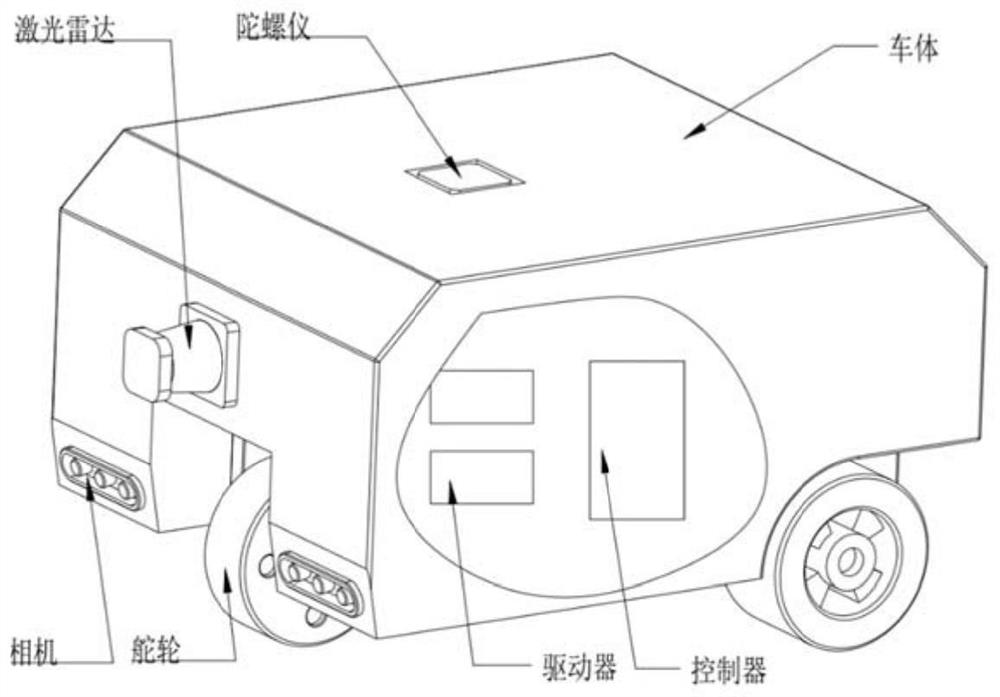
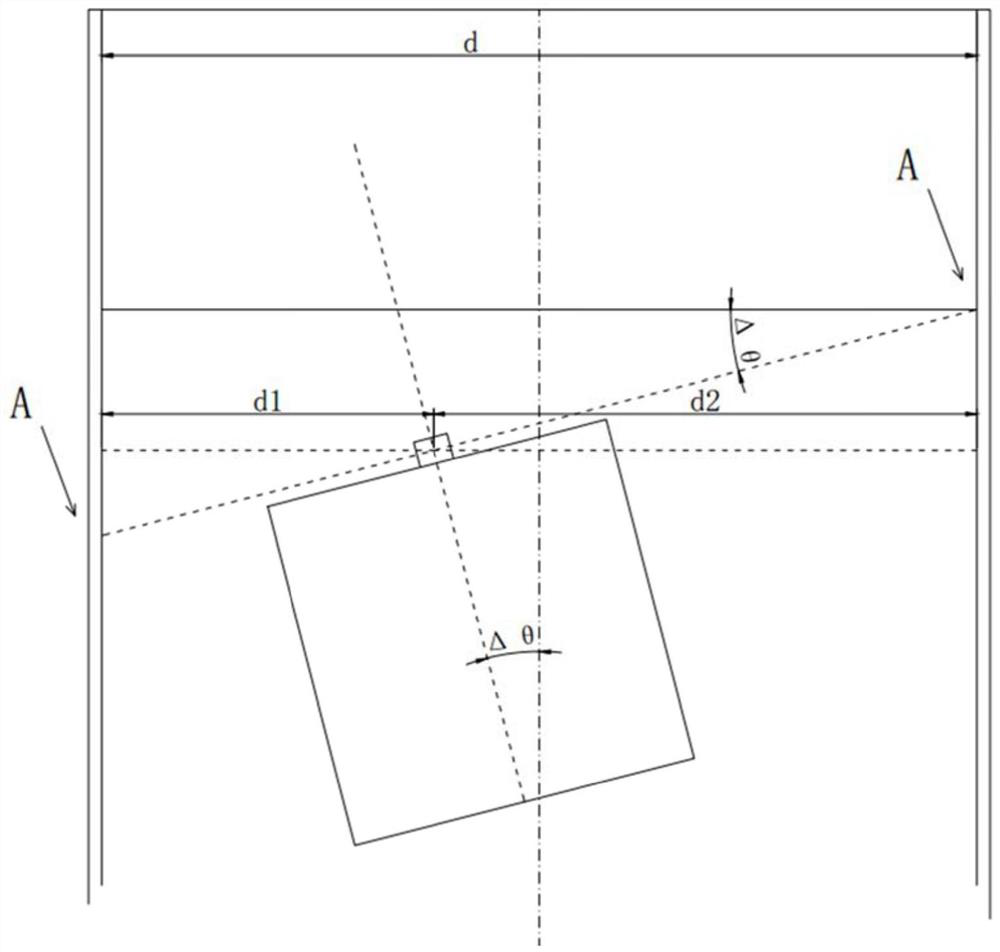
Owner:HUAZHONG UNIV OF SCI & TECH
Adjustable-brightness tunnel lamp
InactiveCN106568060AReduce brightness differenceReduce incidenceMechanical apparatusElectric circuit arrangementsIlluminanceTraffic accident
The invention discloses an adjustable-brightness tunnel lamp. The adjustable-brightness tunnel lamp comprises a lampholder and a lamp body. The lampholder is fixed to the wall near a tunnel portal, and the lamp body is arranged on the lampholder. An LED lamp is adopted for the lamp body and is connected with city power. The adjustable-brightness tunnel lamp further comprises a photoresistor connected between the LED lamp and the city power. The tunnel lamp structure can automatically adjust the illuminance of the tunnel lamp according to the difference of the brightness inside a tunnel and the brightness outside the tunnel, thus a driver can fast adapt to the change of the brightness, and the traffic accident rate is decreased.
Owner:JIANGSU JINMI INTELLIGENT TECH CO LTD
Tunnel lamp
InactiveCN106376137AReduce brightness differenceReduce incidenceElectrical apparatusElectroluminescent light sourcesElectricityEngineering
The invention discloses a tunnel lamp. The tunnel lamp comprises a lamp holder and a lamp body, wherein the lamp holder is fixed on a wall near to a tunnel entrance, the lamp body is arranged on the lamp holder and is connected with a mains supply, the tunnel lamp also comprises an illuminance transducer and a master controller, the lamp body adopts n groups of LED lamps with different colors, n is more than or equal to 2, the illuminance transducer is arranged at the tunnel entrance and is used for sensing illuminance data outside a tunnel and sending the illuminance data to the master controller, the master controller is used for adjusting a brightness value of each group of LED lamps according to the illuminance data, so that required illuminance is obtained after all LED lamps are mixed. By the tunnel lamp structure, the illuminance of the tunnel lamp can be automatically adjusted according to light brightness outside the tunnel, so that a driver can quickly adapt to brightness change during going through the tunnel, and the occurrence rate of a traffic accident is reduced.
Owner:JIANGSU JINMI INTELLIGENT TECH CO LTD
Integrally-formed hub
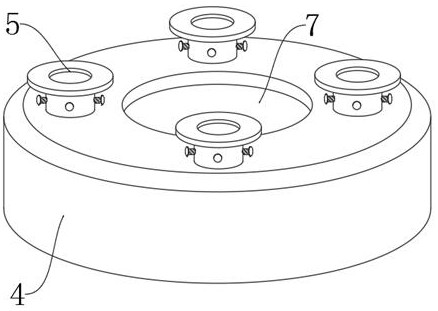
The invention relates to the technical field of vehicle assembly, in particular to an integrally-formed hub, comprising a hub body, wherein a mounting disc is mounted inside the hub body; a frameworkis fixedly connected between the hub body and the mounting disc; the hub body, the mounting disc and the framework are connected by integrally forming, and a bearing mechanism is mounted on the innerside surface of the mounting disc; and a reinforcing mechanism is arranged at the side end of the bearing mechanism and connected to the side end of the bearing mechanism. The reinforcing mechanism isarranged at the outer end of the bearing mechanism, so that when an axle is connected to the hub body through a bolt piece, the reinforcing mechanism sleeves the exterior of the bolt piece, and meanwhile, a fastener in a sleeving piece is screwed, so that the fastener can abut against the exterior of the bolt piece, the bolt piece is connected to the hub body and the axle more stably; and meanwhile, after the outer part of the hub body is disengaged from a bolt piece connecting nut, the axle is prevented from being directly separated from the hub body, thus improving the driving safety, and guaranteeing normal and stable traveling of a vehicle.
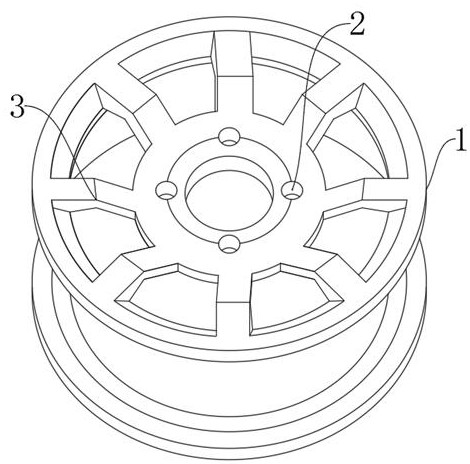
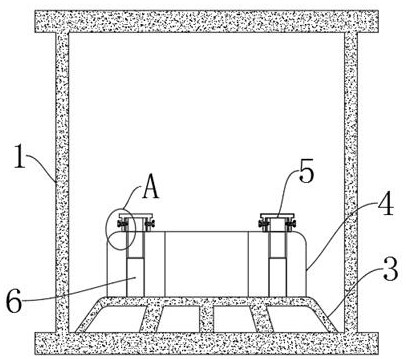
Owner:衡阳市振洋汽车配件有限公司
Hybrid vehicle group cooperative control method based on cloud edge cooperative architecture
ActiveCN119418523ASimple control algorithmstable drivingControl with pedestrian guidance indicatorDetection of traffic movementSimulationHybrid vehicle
The invention relates to a hybrid vehicle group cooperative control method based on a cloud edge cooperative architecture, and belongs to the technical field of intelligent traffic. The method comprises the following steps: S1, setting an urban road single-lane heterogeneous traffic scene under a cloud edge collaborative architecture; s2, on the cloud server, based on the heterogeneous vehicle kinematics characteristics, establishing a longitudinal kinematics model for driving of the networked automatic vehicle and a longitudinal kinematics model for driving of the networked person; s3, the vehicle state information data and the vehicle longitudinal kinematics model uploaded to the cloud server are obtained and analyzed, and a networked person driving cooperative driving model and a networked automatic vehicle control algorithm considering mutual influence between the vehicles are constructed on the cloud server in combination with a vehicle information topological structure; s4, establishing a state-space equation of heterogeneous vehicles, integrating the networked automatic vehicle control algorithm and the networked person driving cooperative driving model, and constructing a hybrid vehicle group kinematics state equation; and S5, establishing a hybrid vehicle group cooperative control method. The method effectively ensures that the hybrid vehicle group rapidly realizes consistent and stable driving.

Owner:CHONGQING UNIV OF POSTS & TELECOMM