
Patents
Literature
70 results about "Error band" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Error Band (more meaningful than Linearity) Error band is a measurement of worst case error. This is the best specification (compared to linearity) to determine gauge suitability for an application. The Error Band specification describes a bipolar band (i.e. ±0.2%) around the ideal line.
Calculation of state of charge offset using a closed integral method
InactiveUS7233128B2Eliminate hysteresisCircuit monitoring/indicationEmergency protective circuit arrangementsHysteresisBattery state of charge
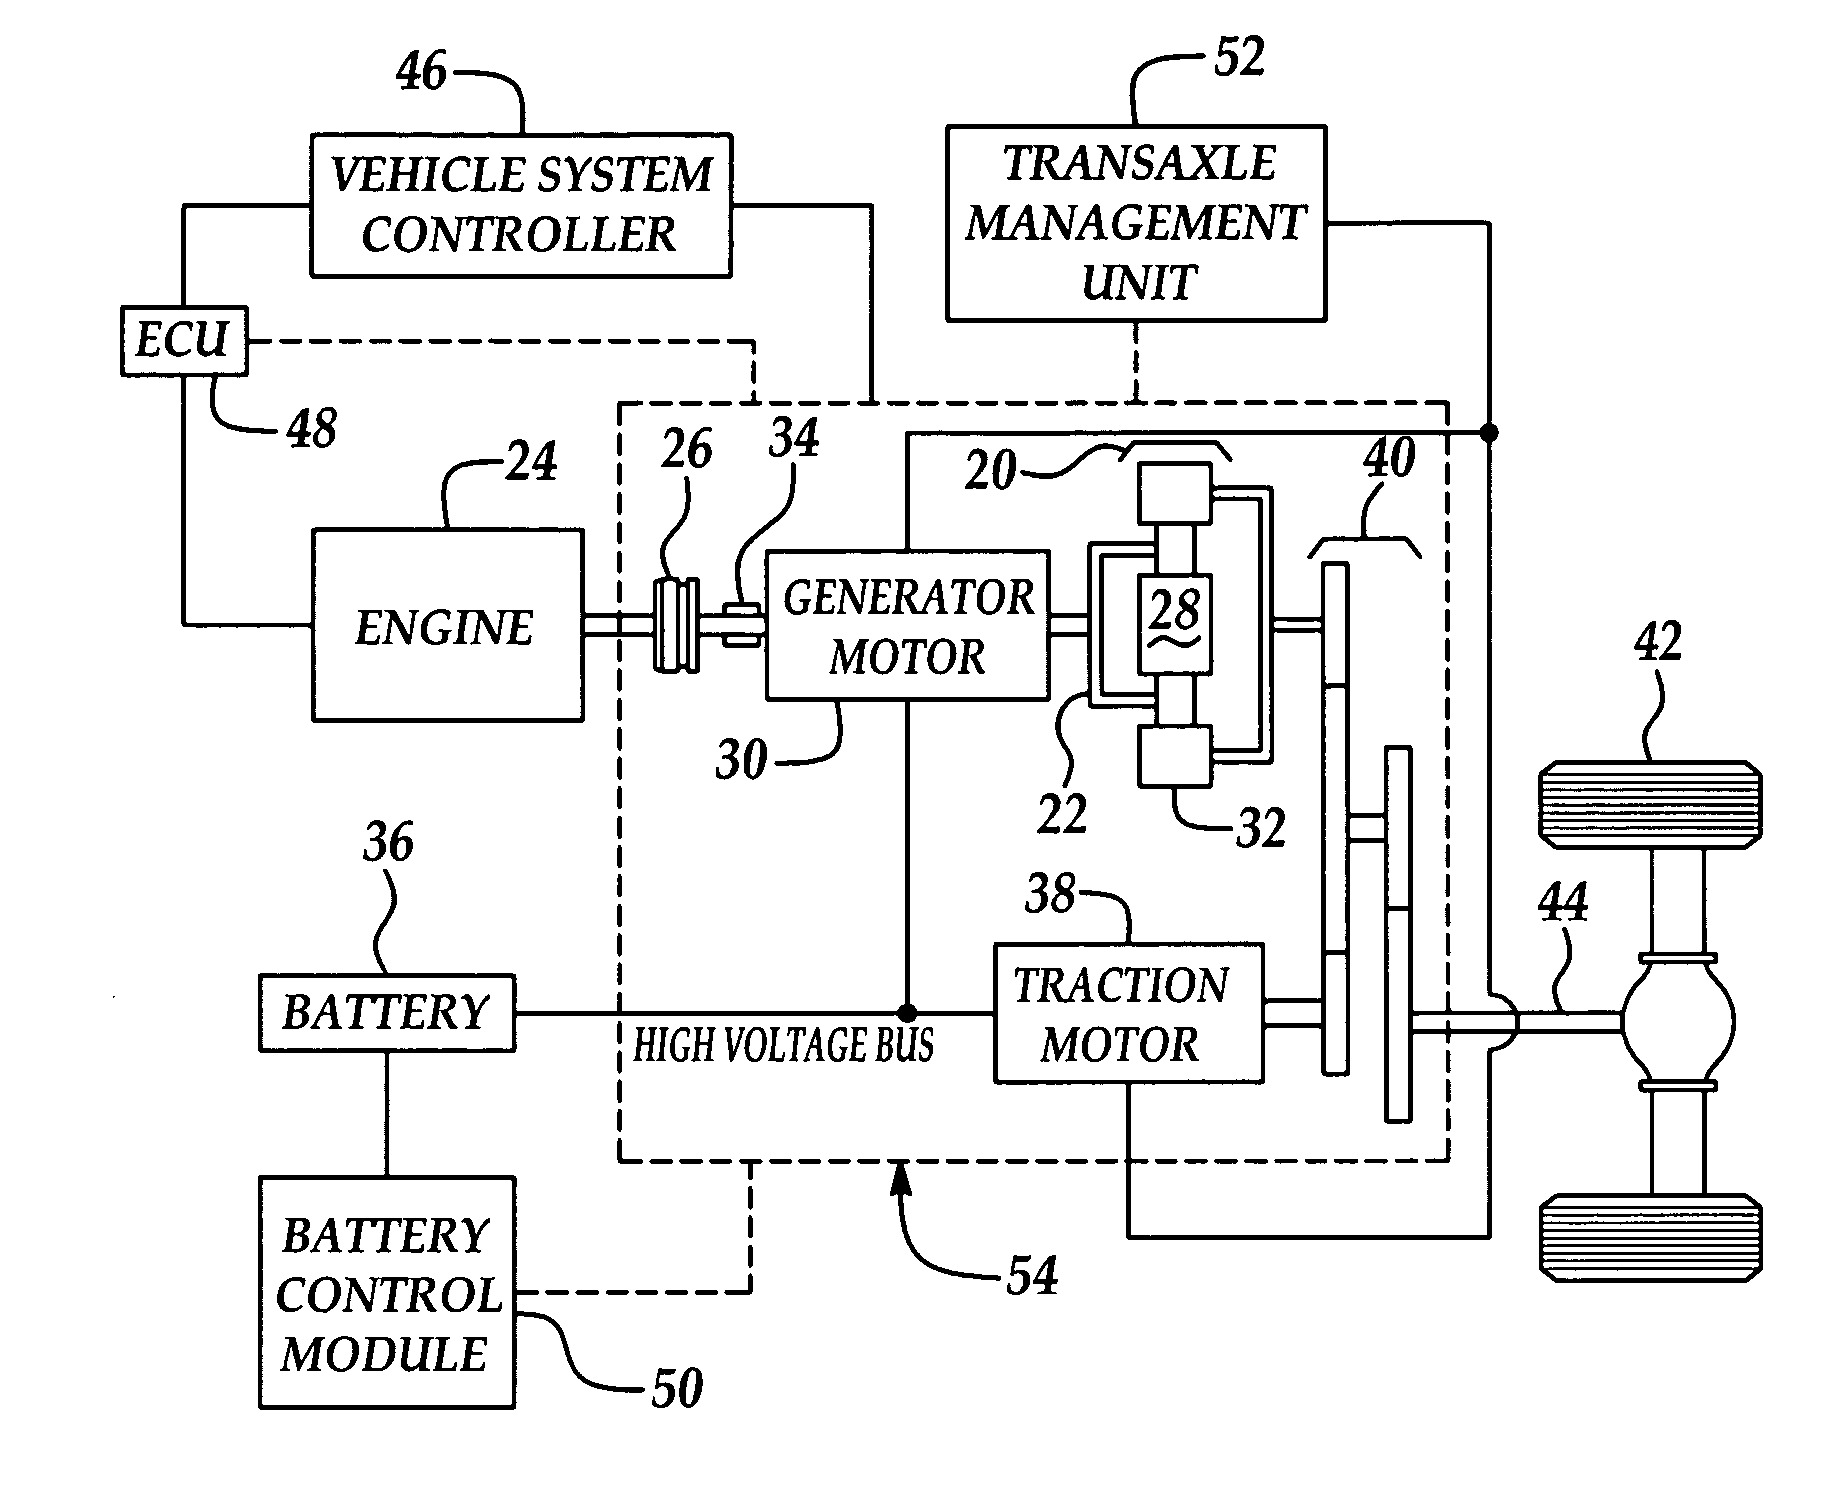
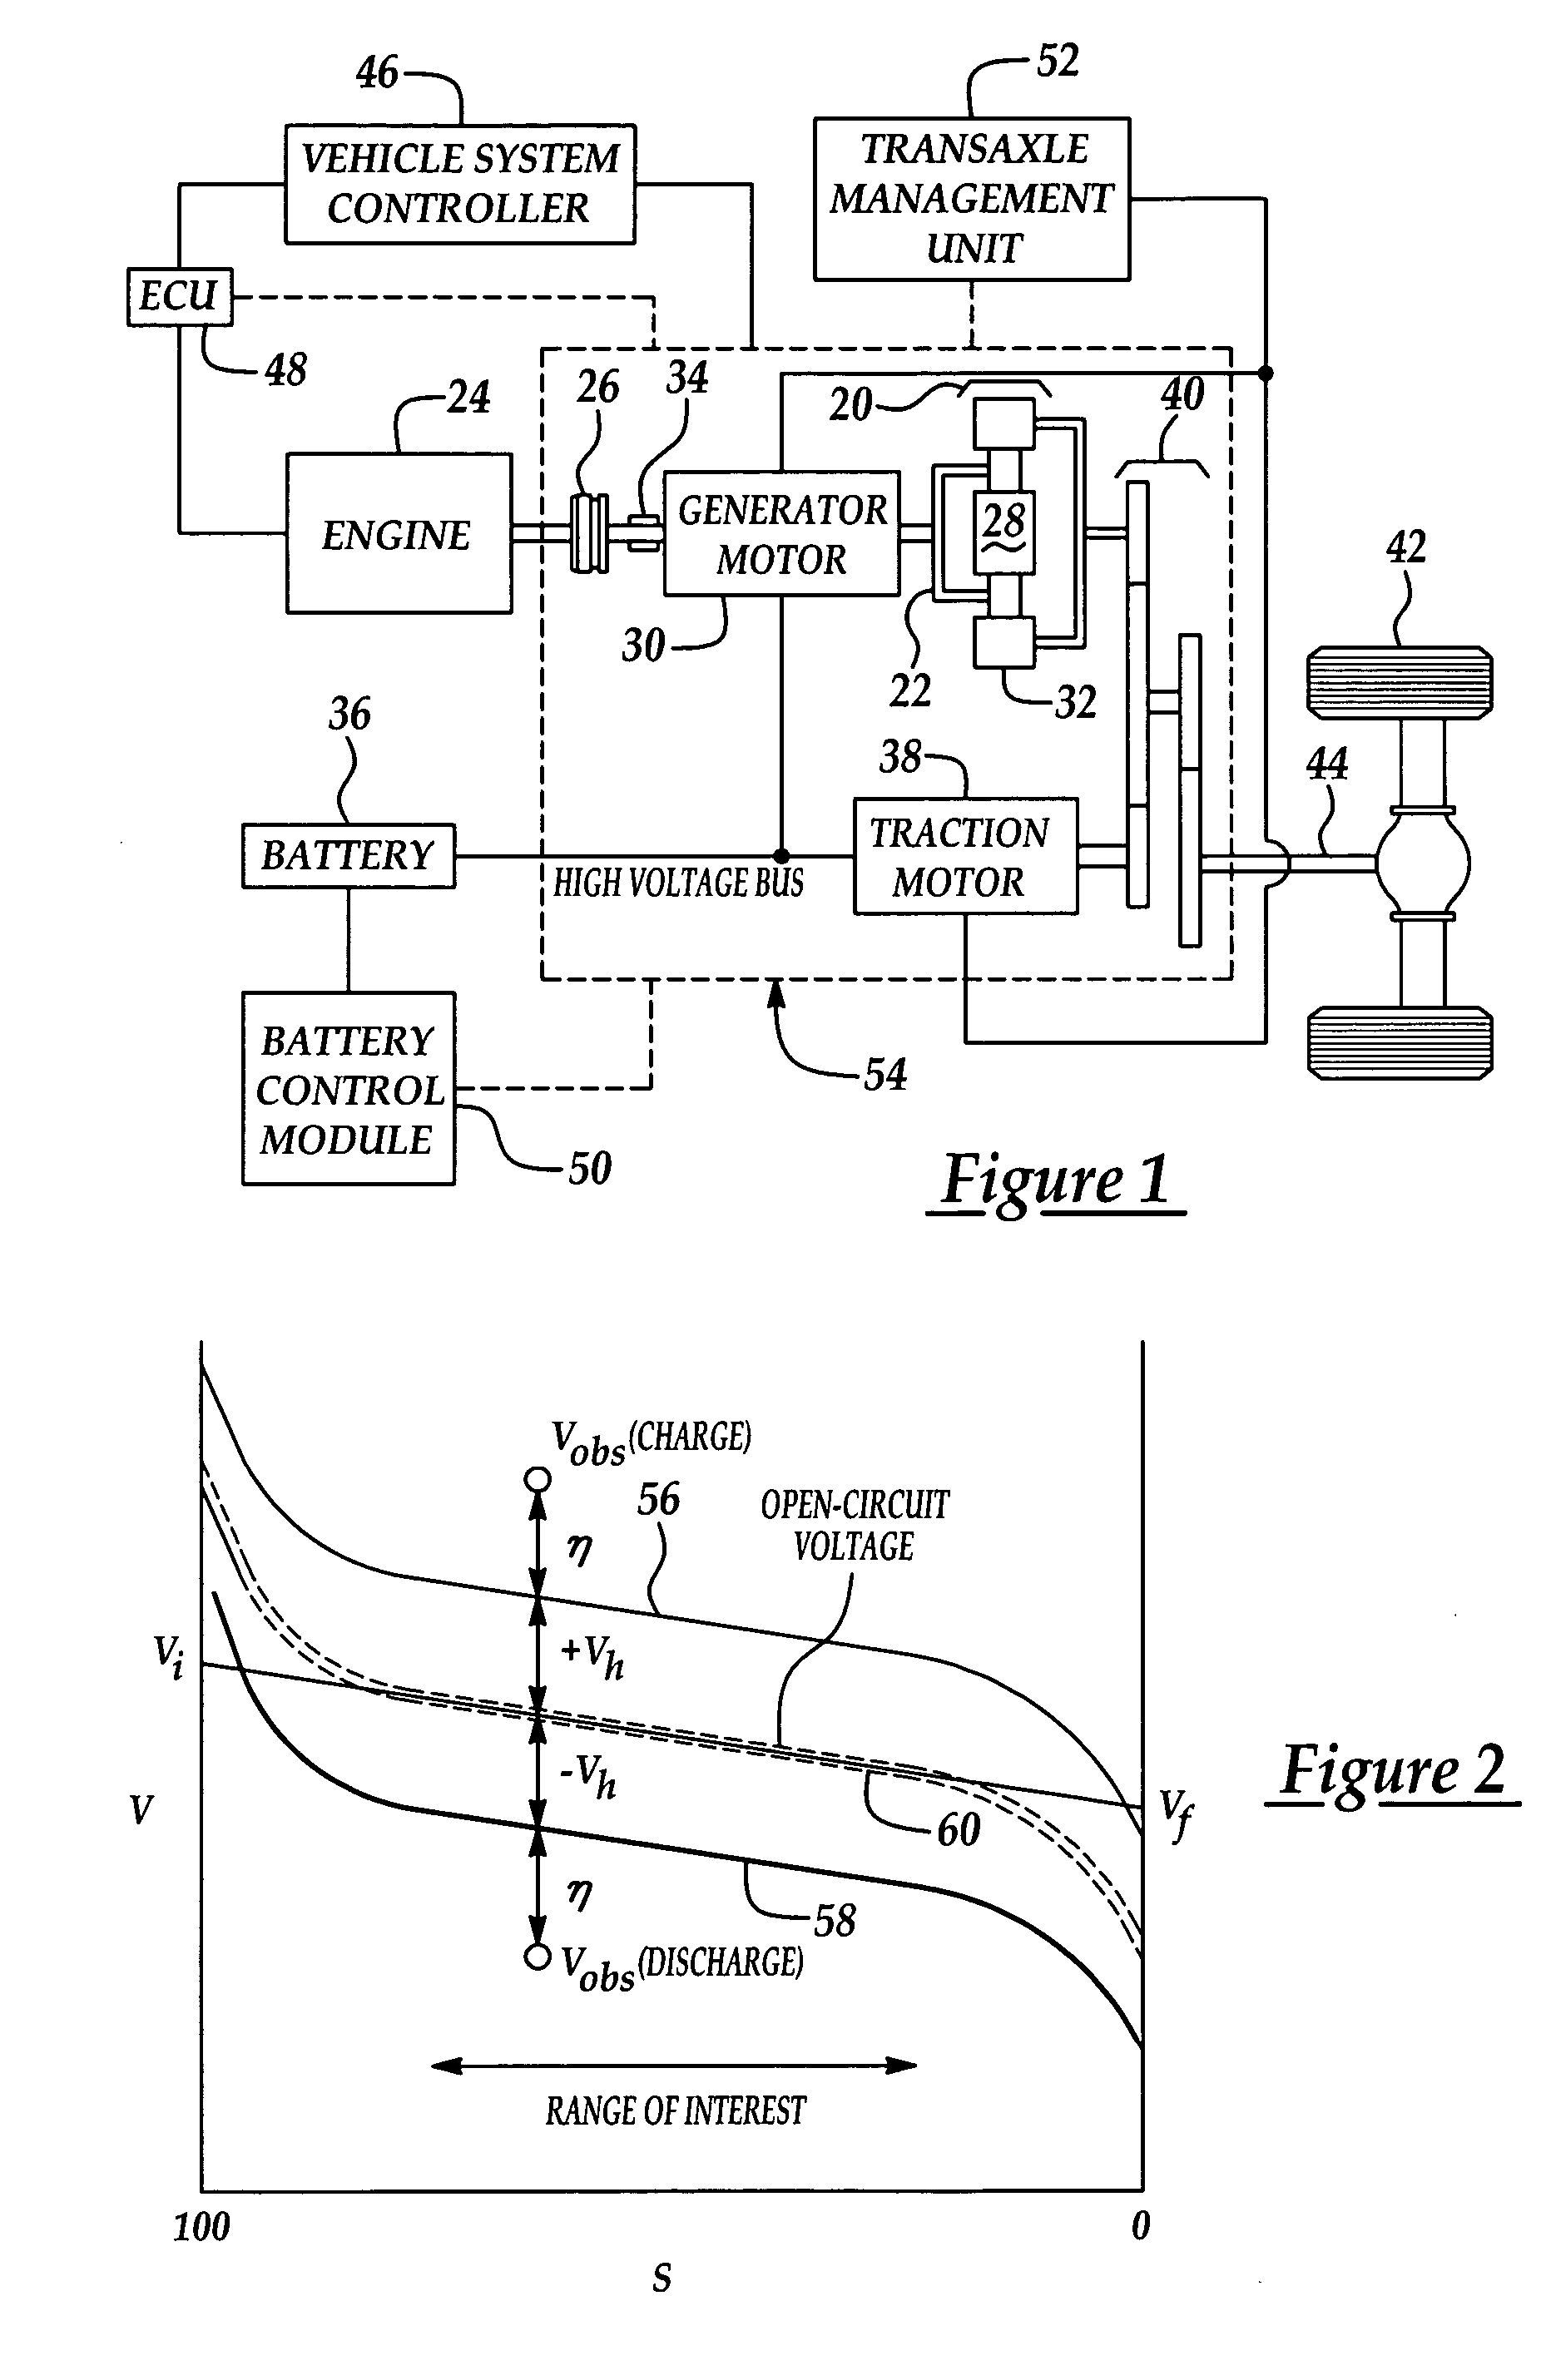
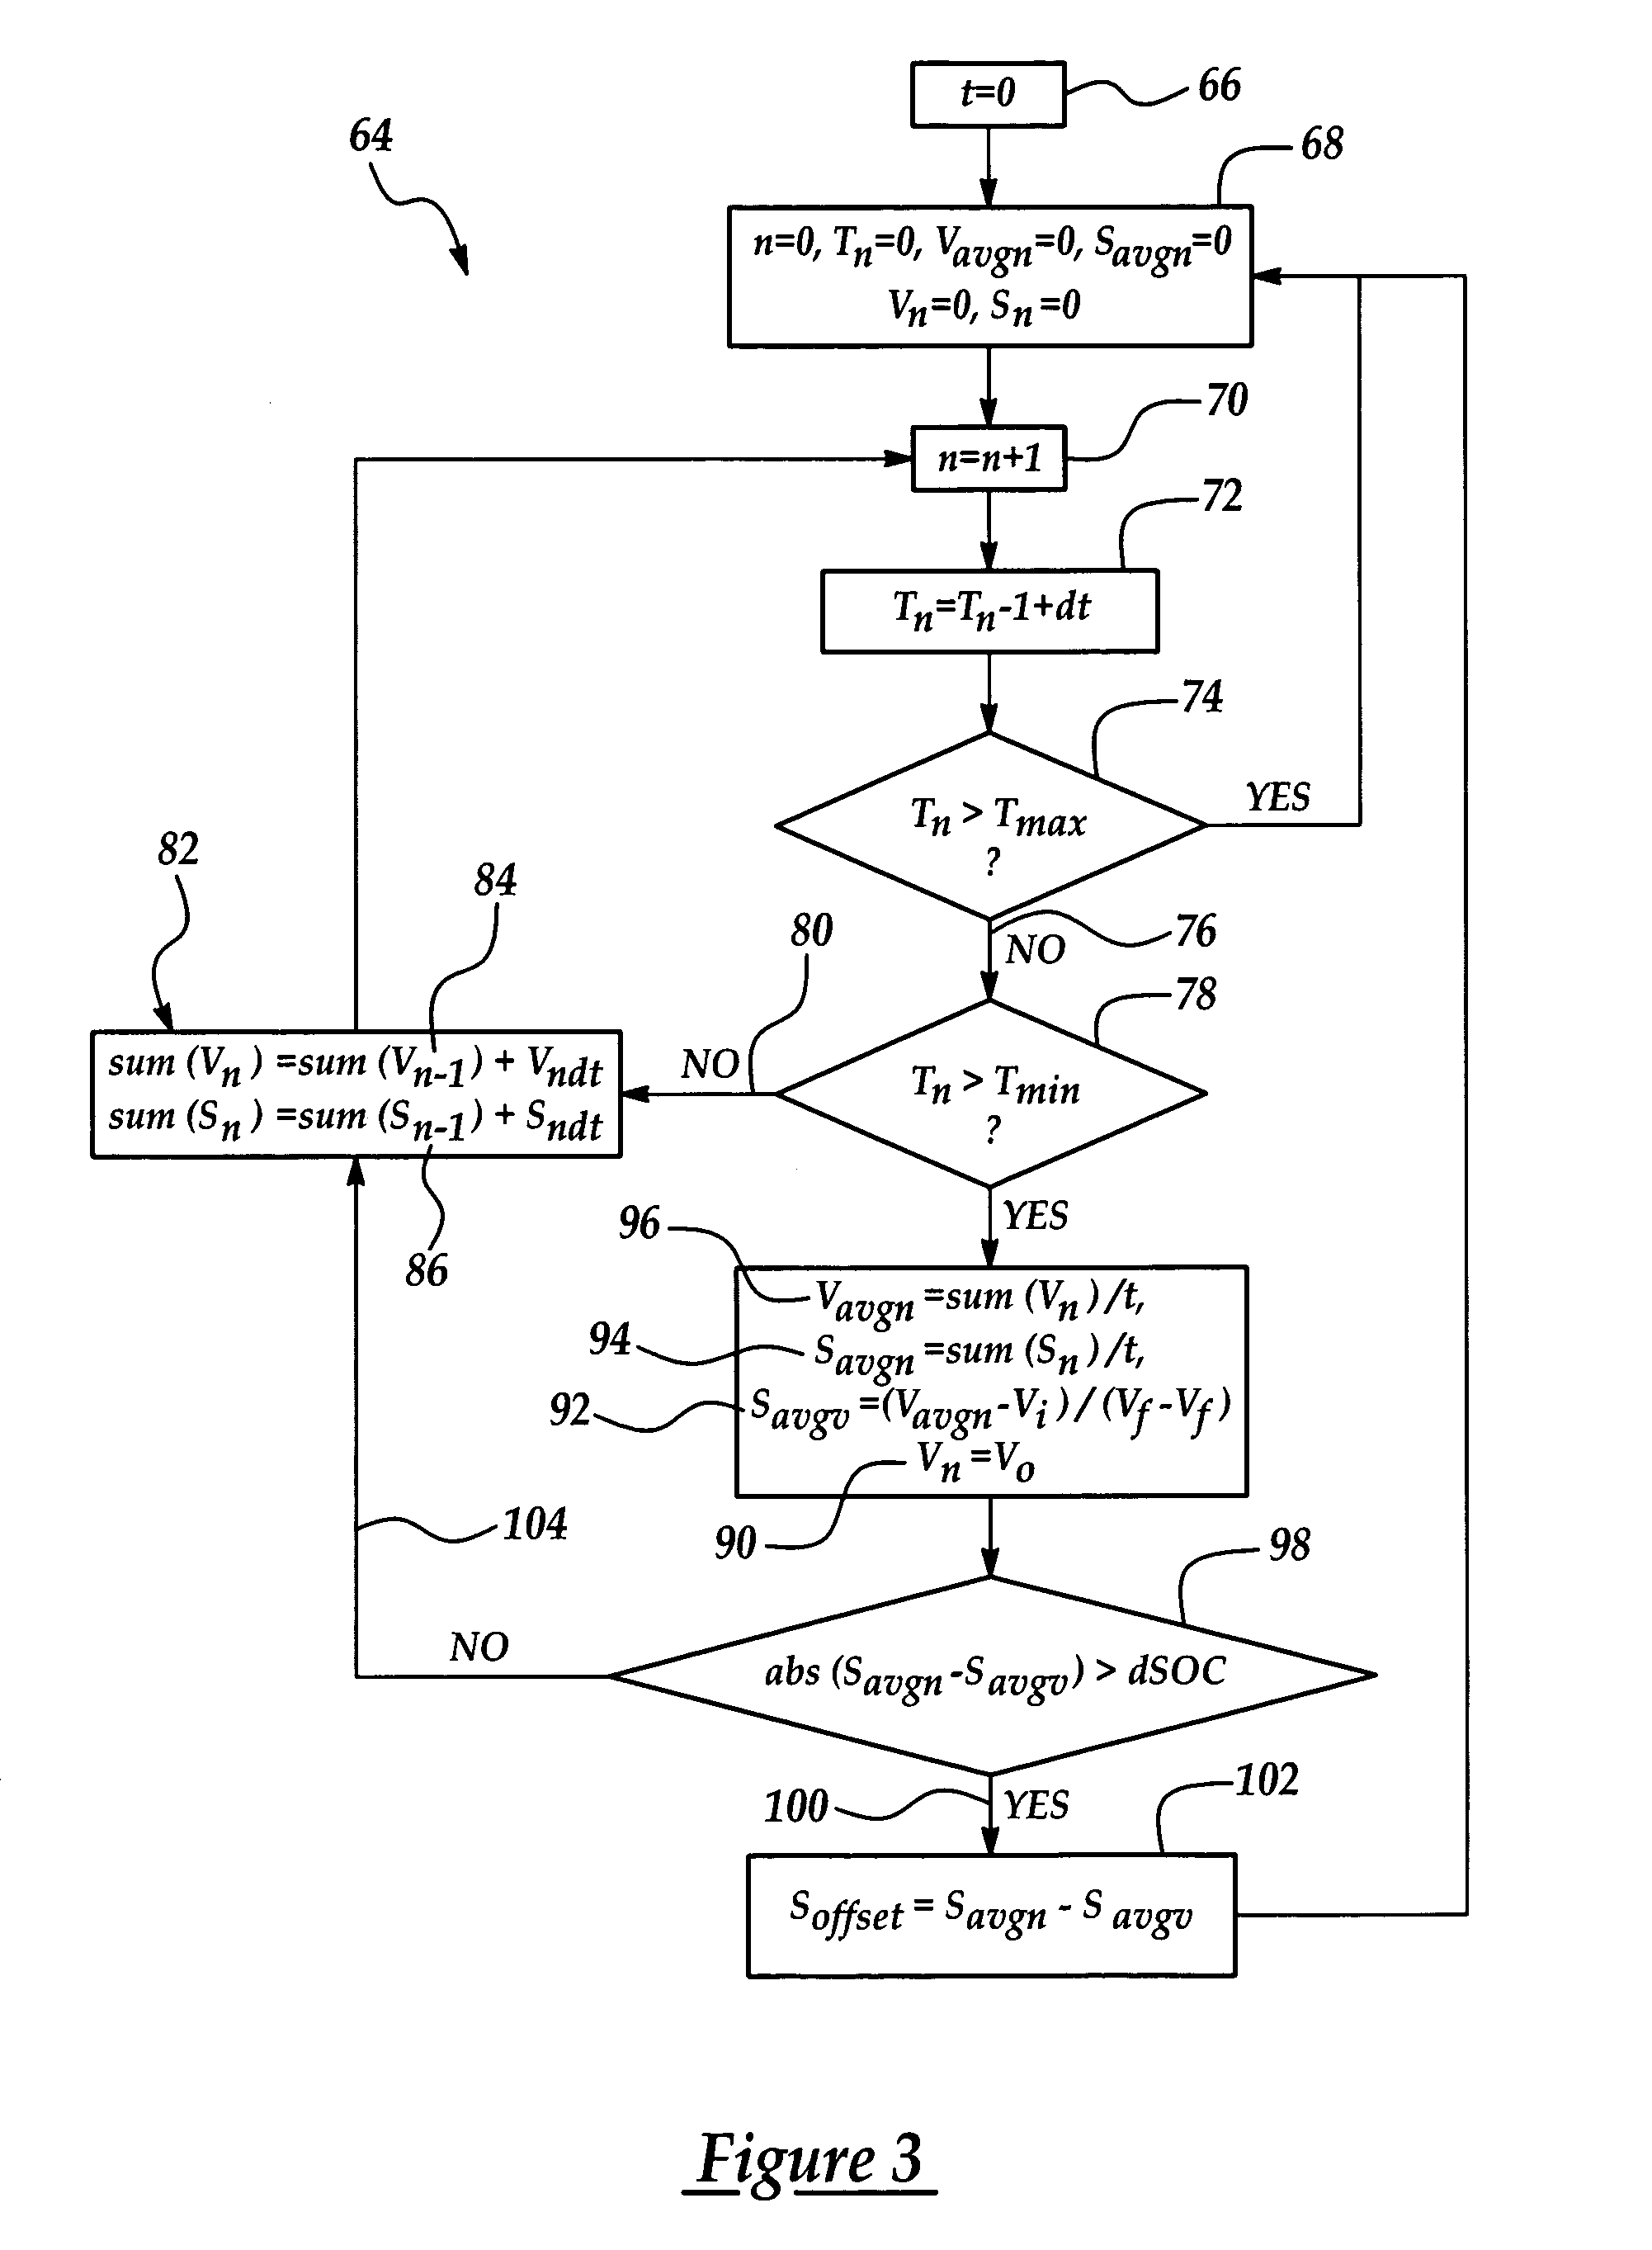
Owner:FORD GLOBAL TECH LLC
Mass spectrometer
ActiveUS20050023454A1Reduce the possibilityAccurate limitParticle separator tubesIsotope separationMass analyzerErrors and residuals
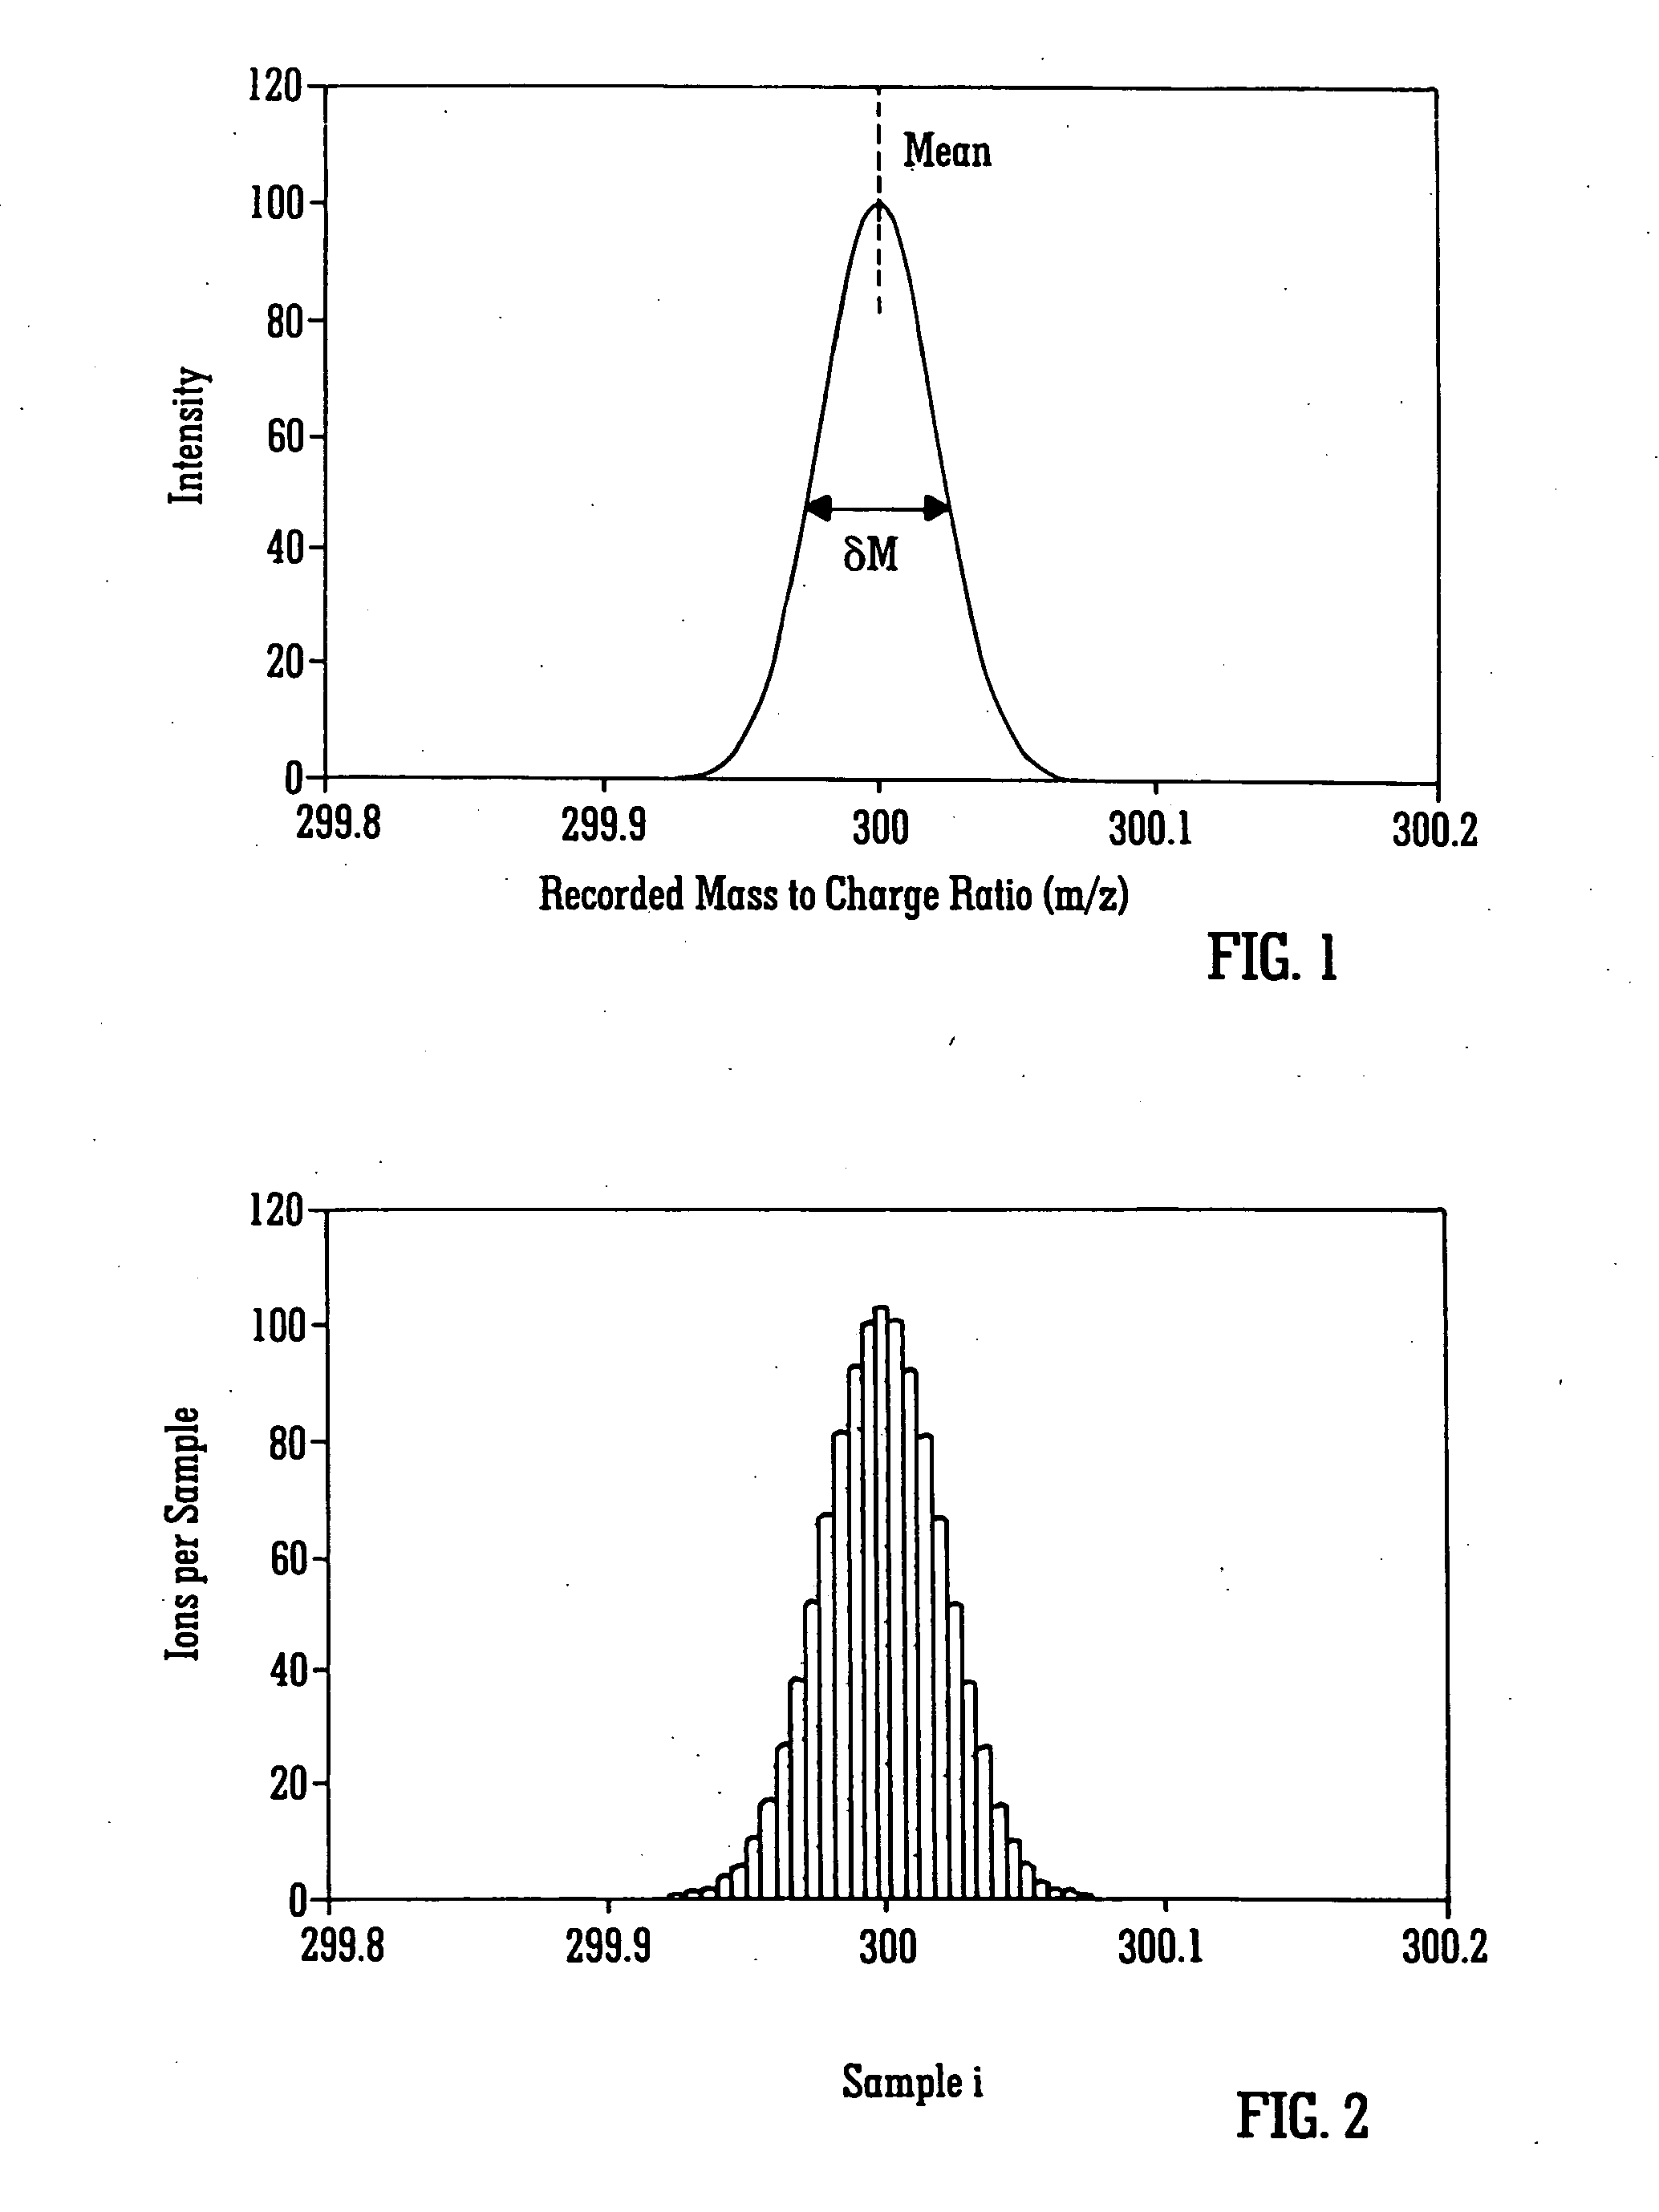
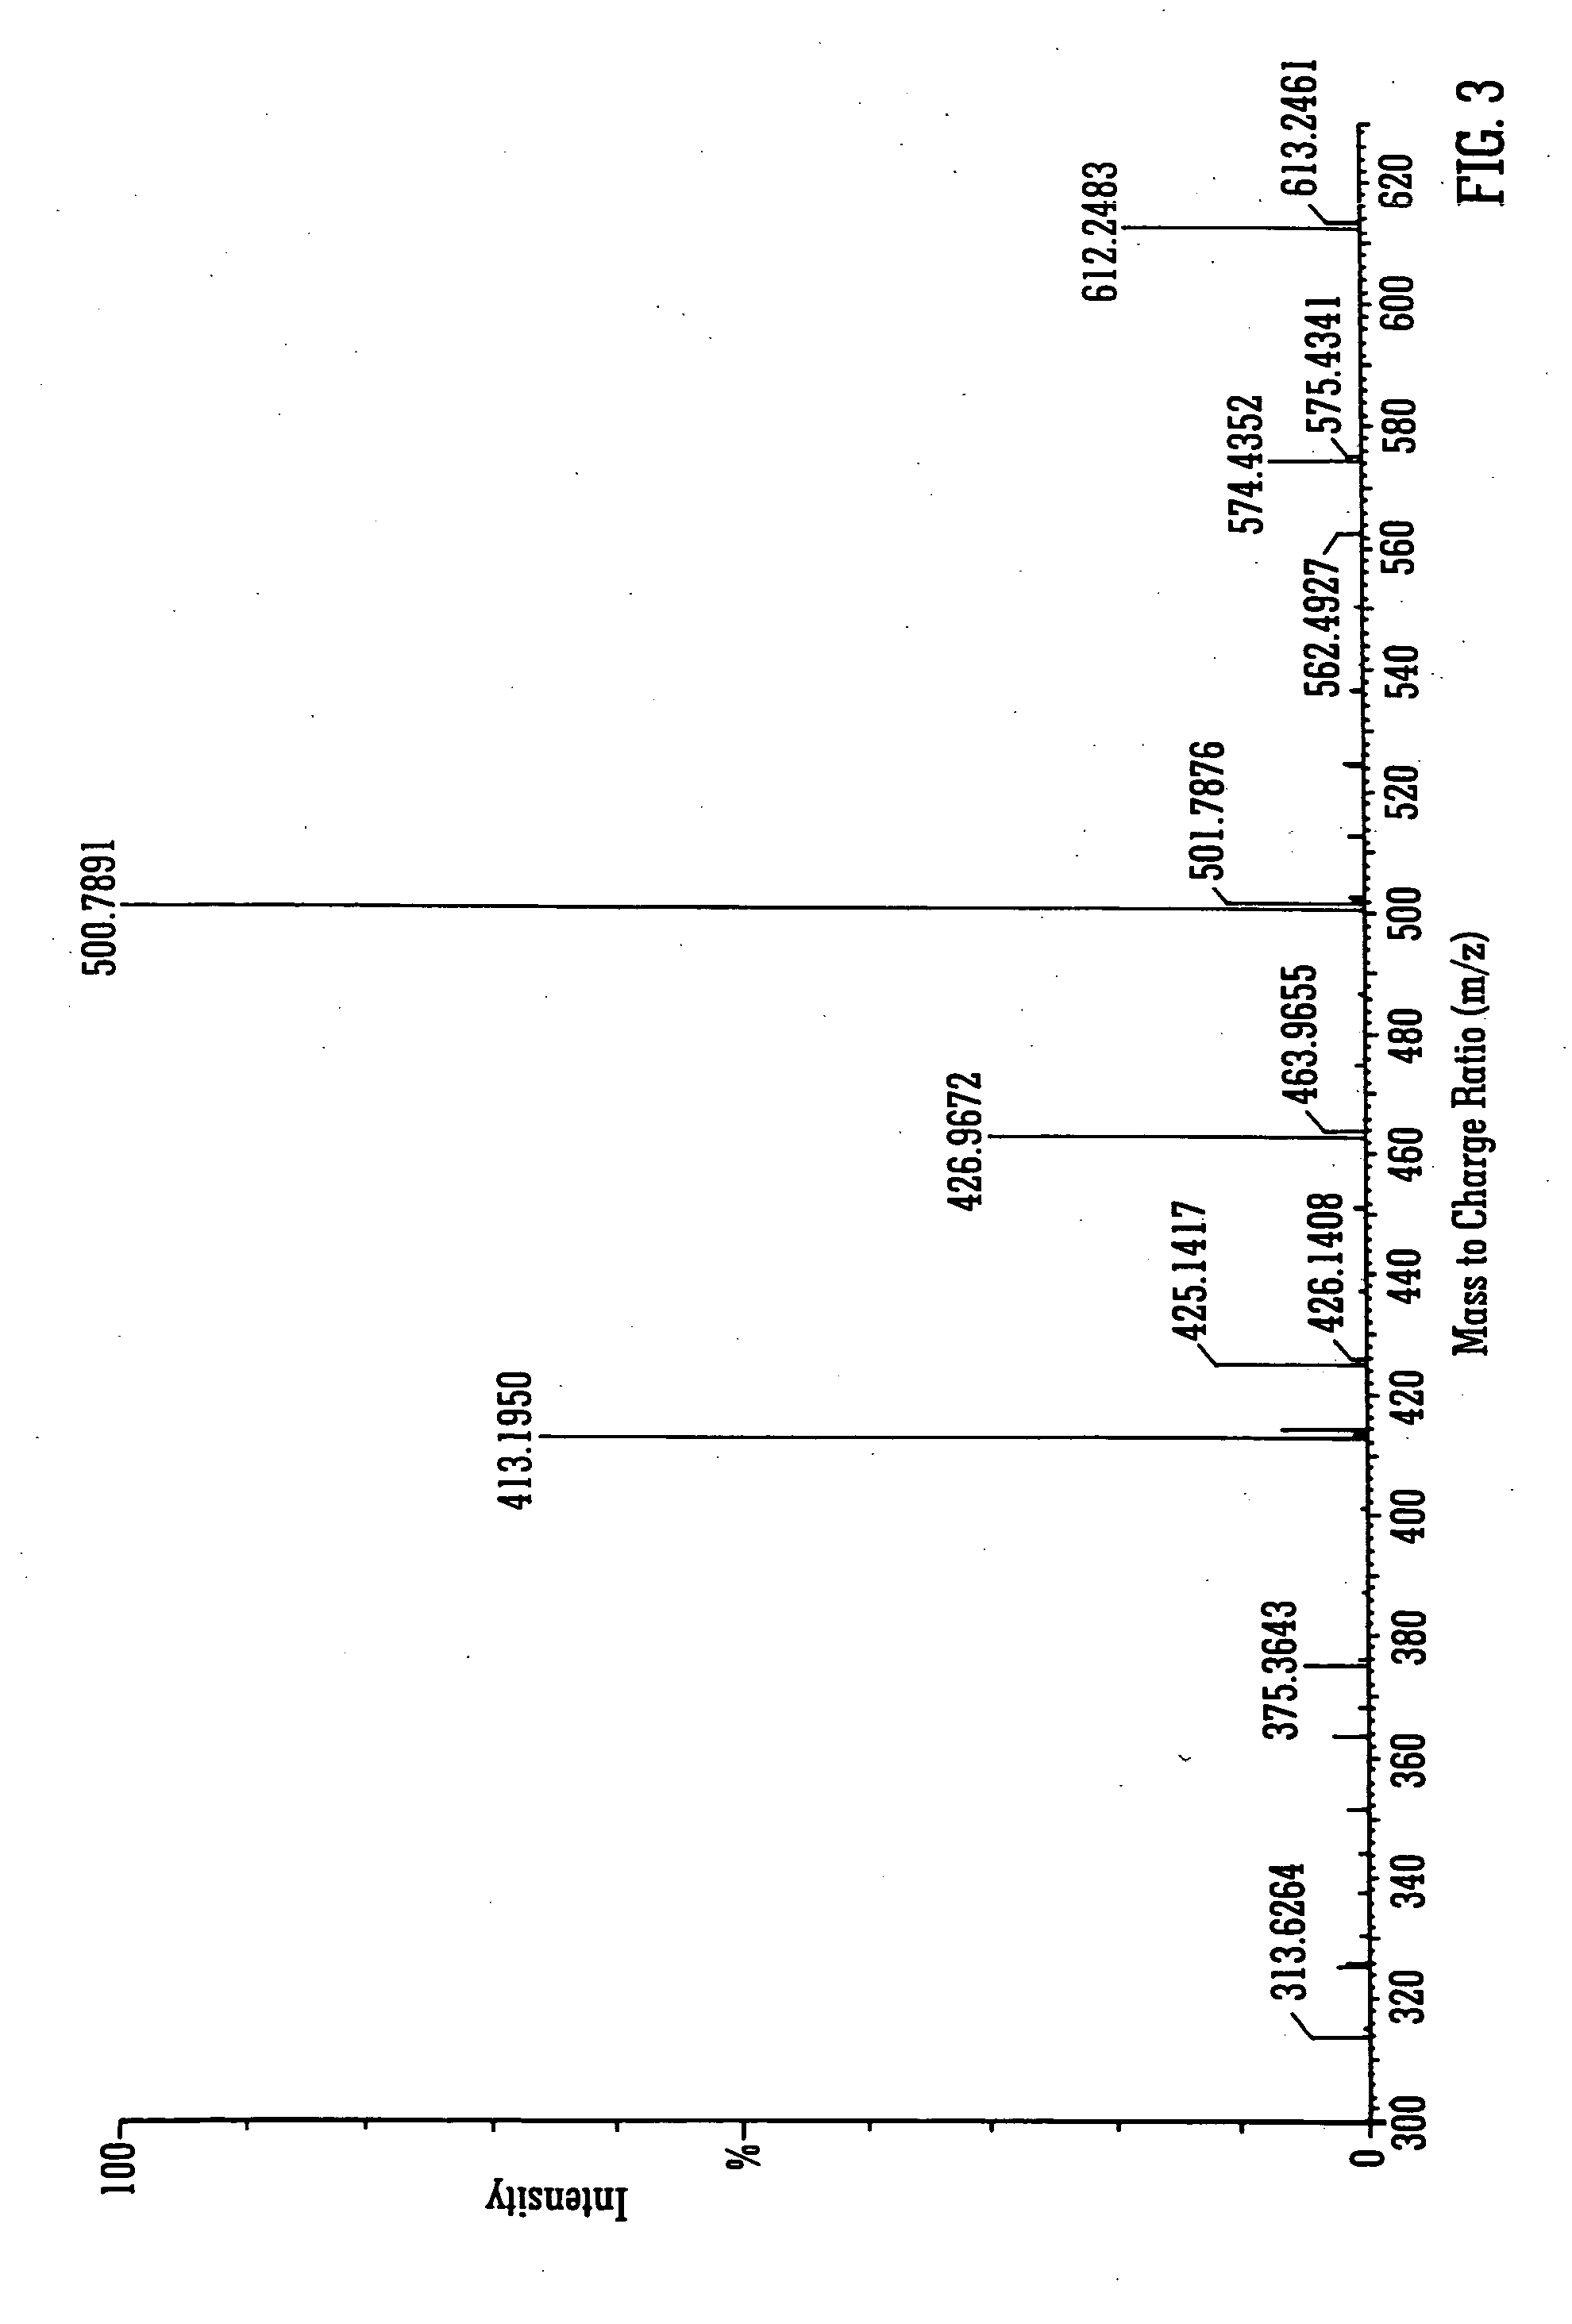
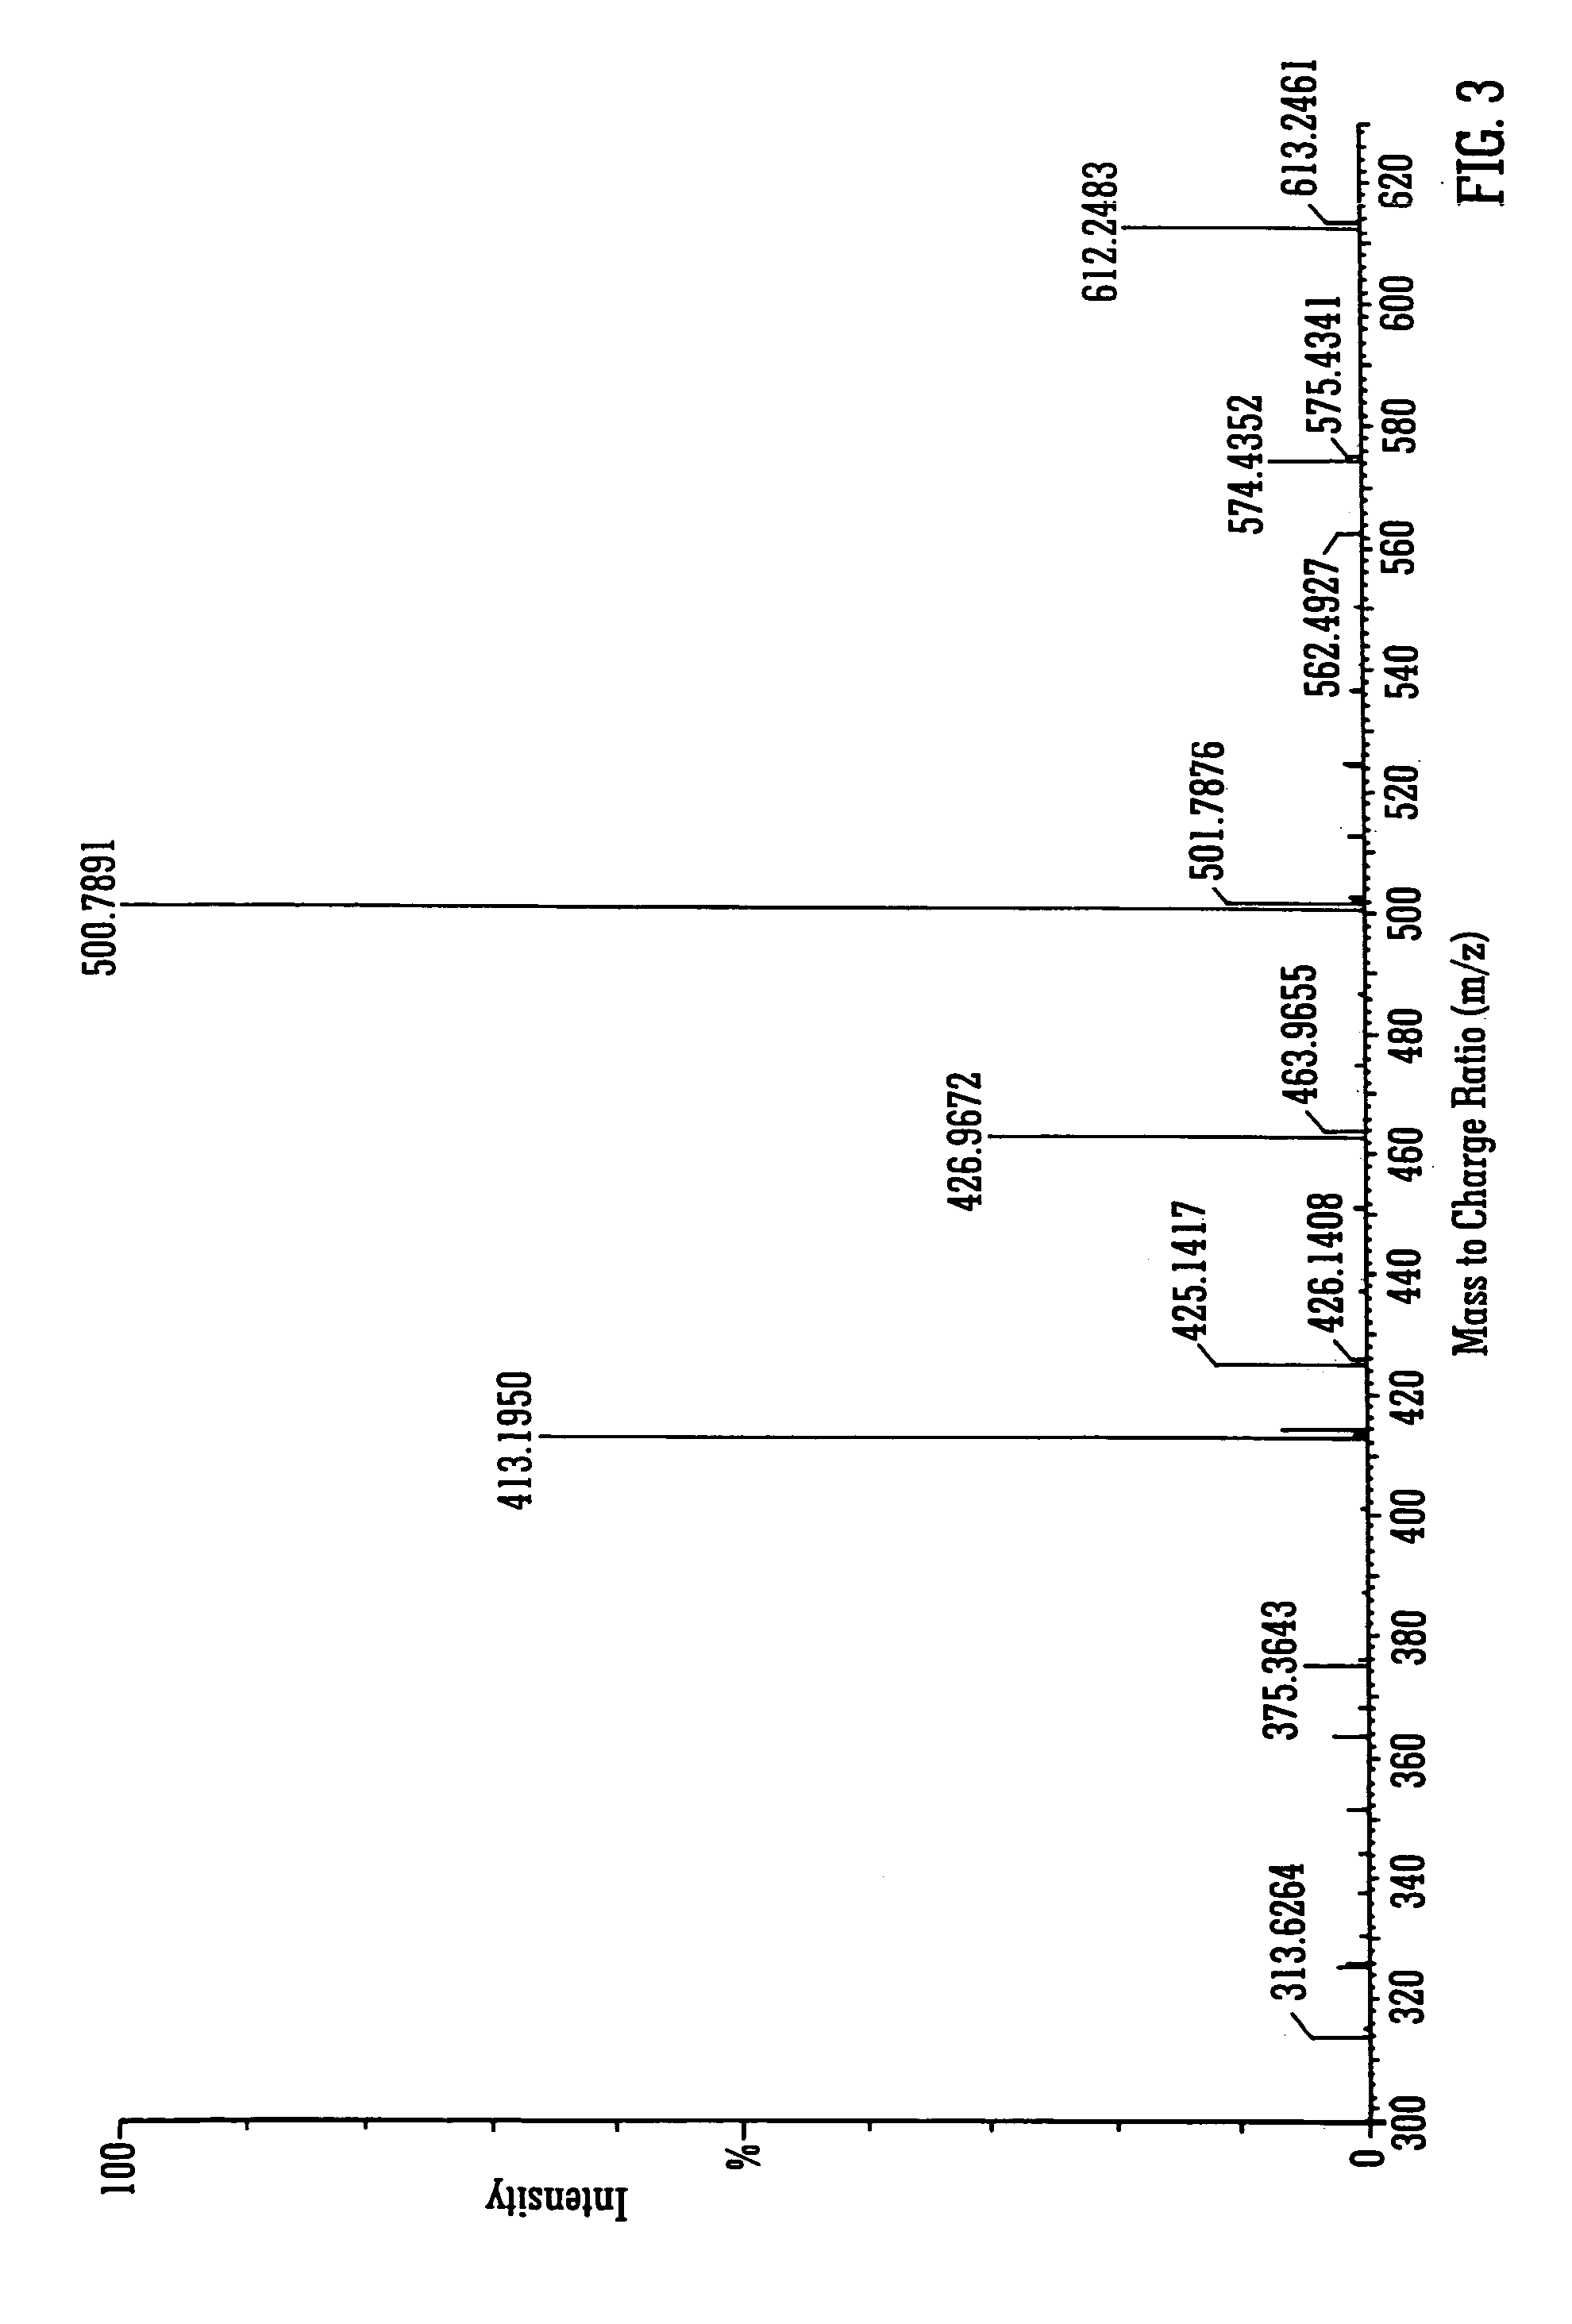
A mass spectrometer is disclosed wherein the experimentally determined mass to charge ratios of ions are reported together with an error band for each mass to charge ratio determination. The error band may, for example, reflect a 95% probability or confidence that the real, true, actual or accepted mass to charge ratio of the ion lies within the error band. By accurately determining the error band the possible candidate ions in a database can be accurately restricted whilst also guarding against over restriction.
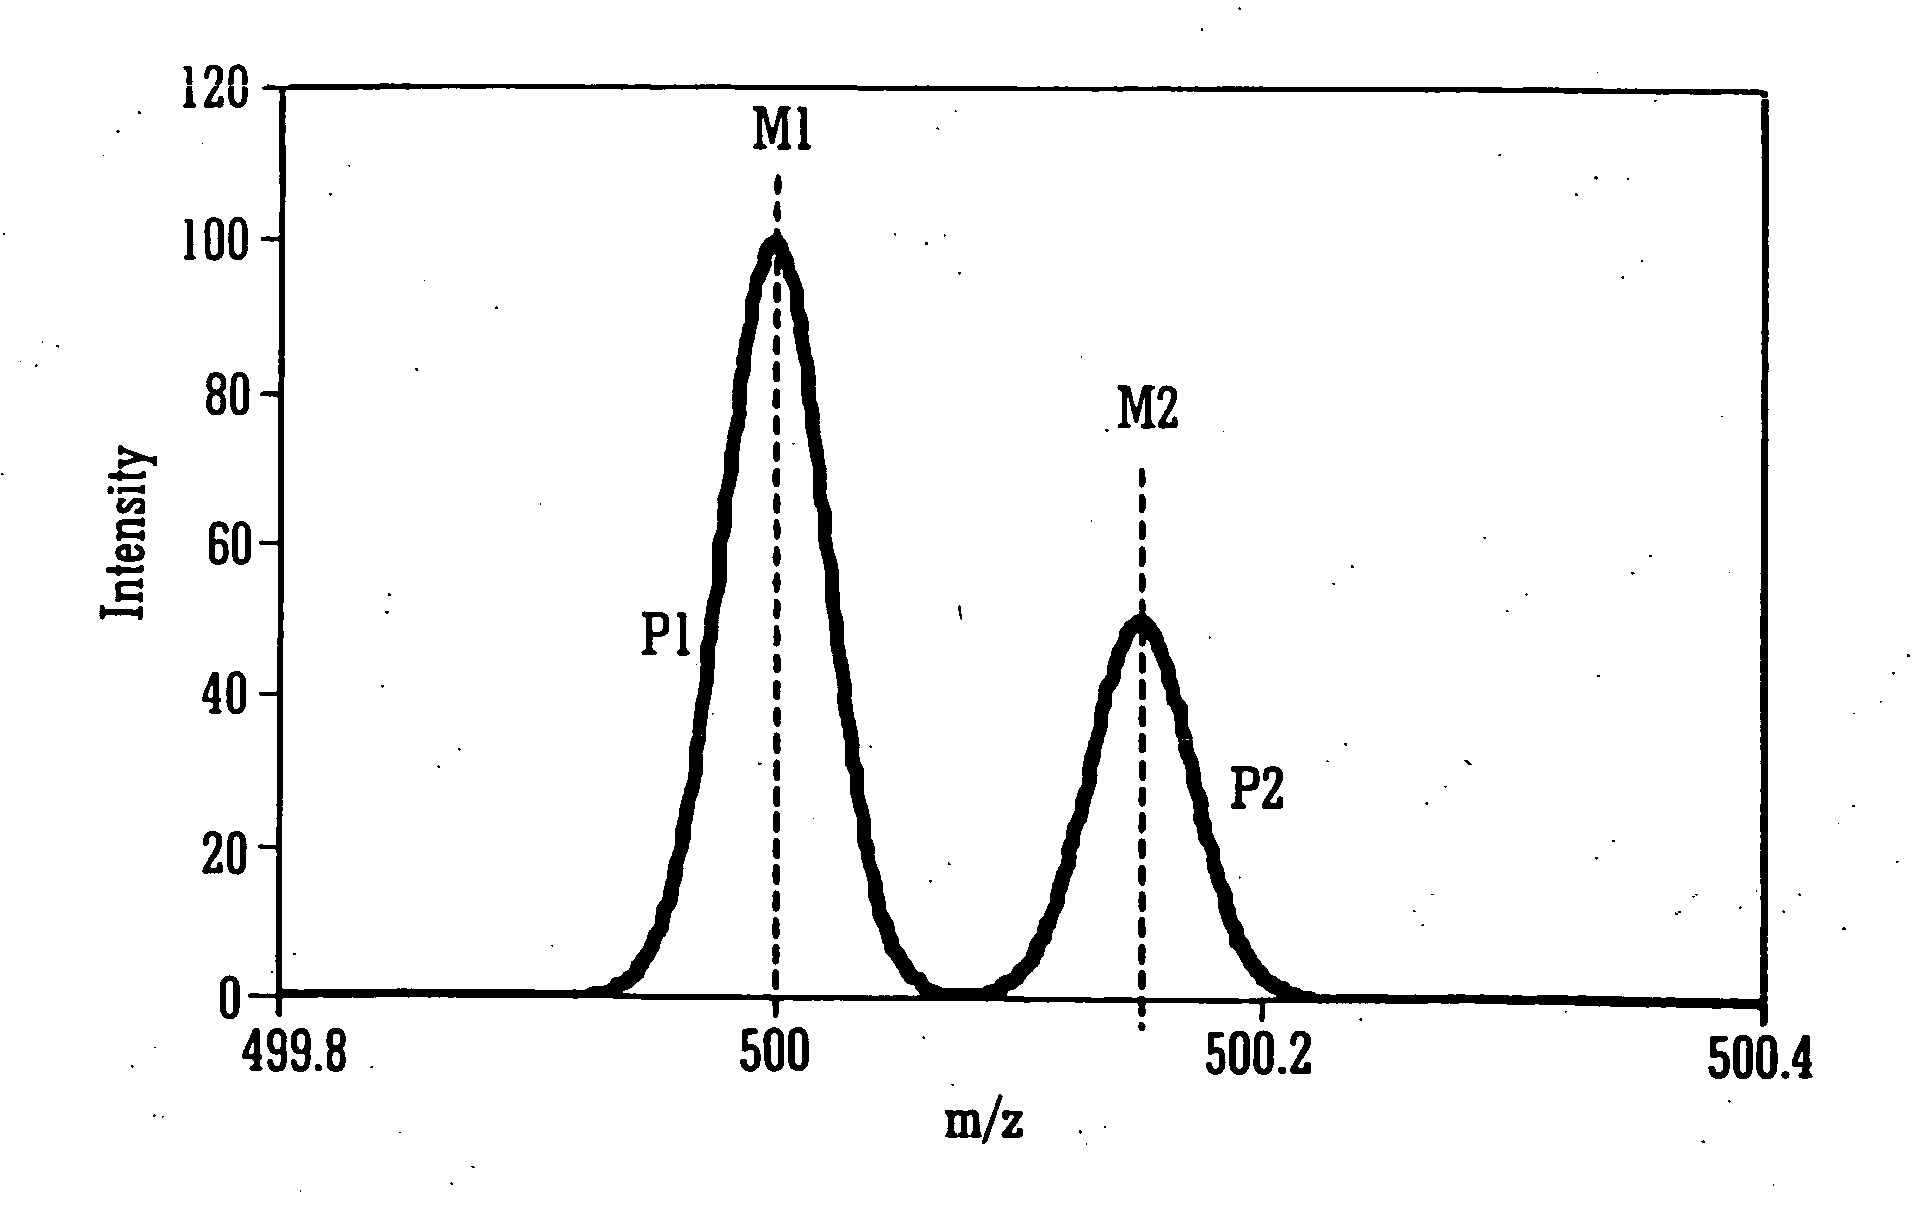
Owner:MICROMASS UK LTD
Mass spectrometer
ActiveUS7202473B2Reduce the possibilityAccurate limitTime-of-flight spectrometersIsotope separationMass-to-charge ratioErrors and residuals
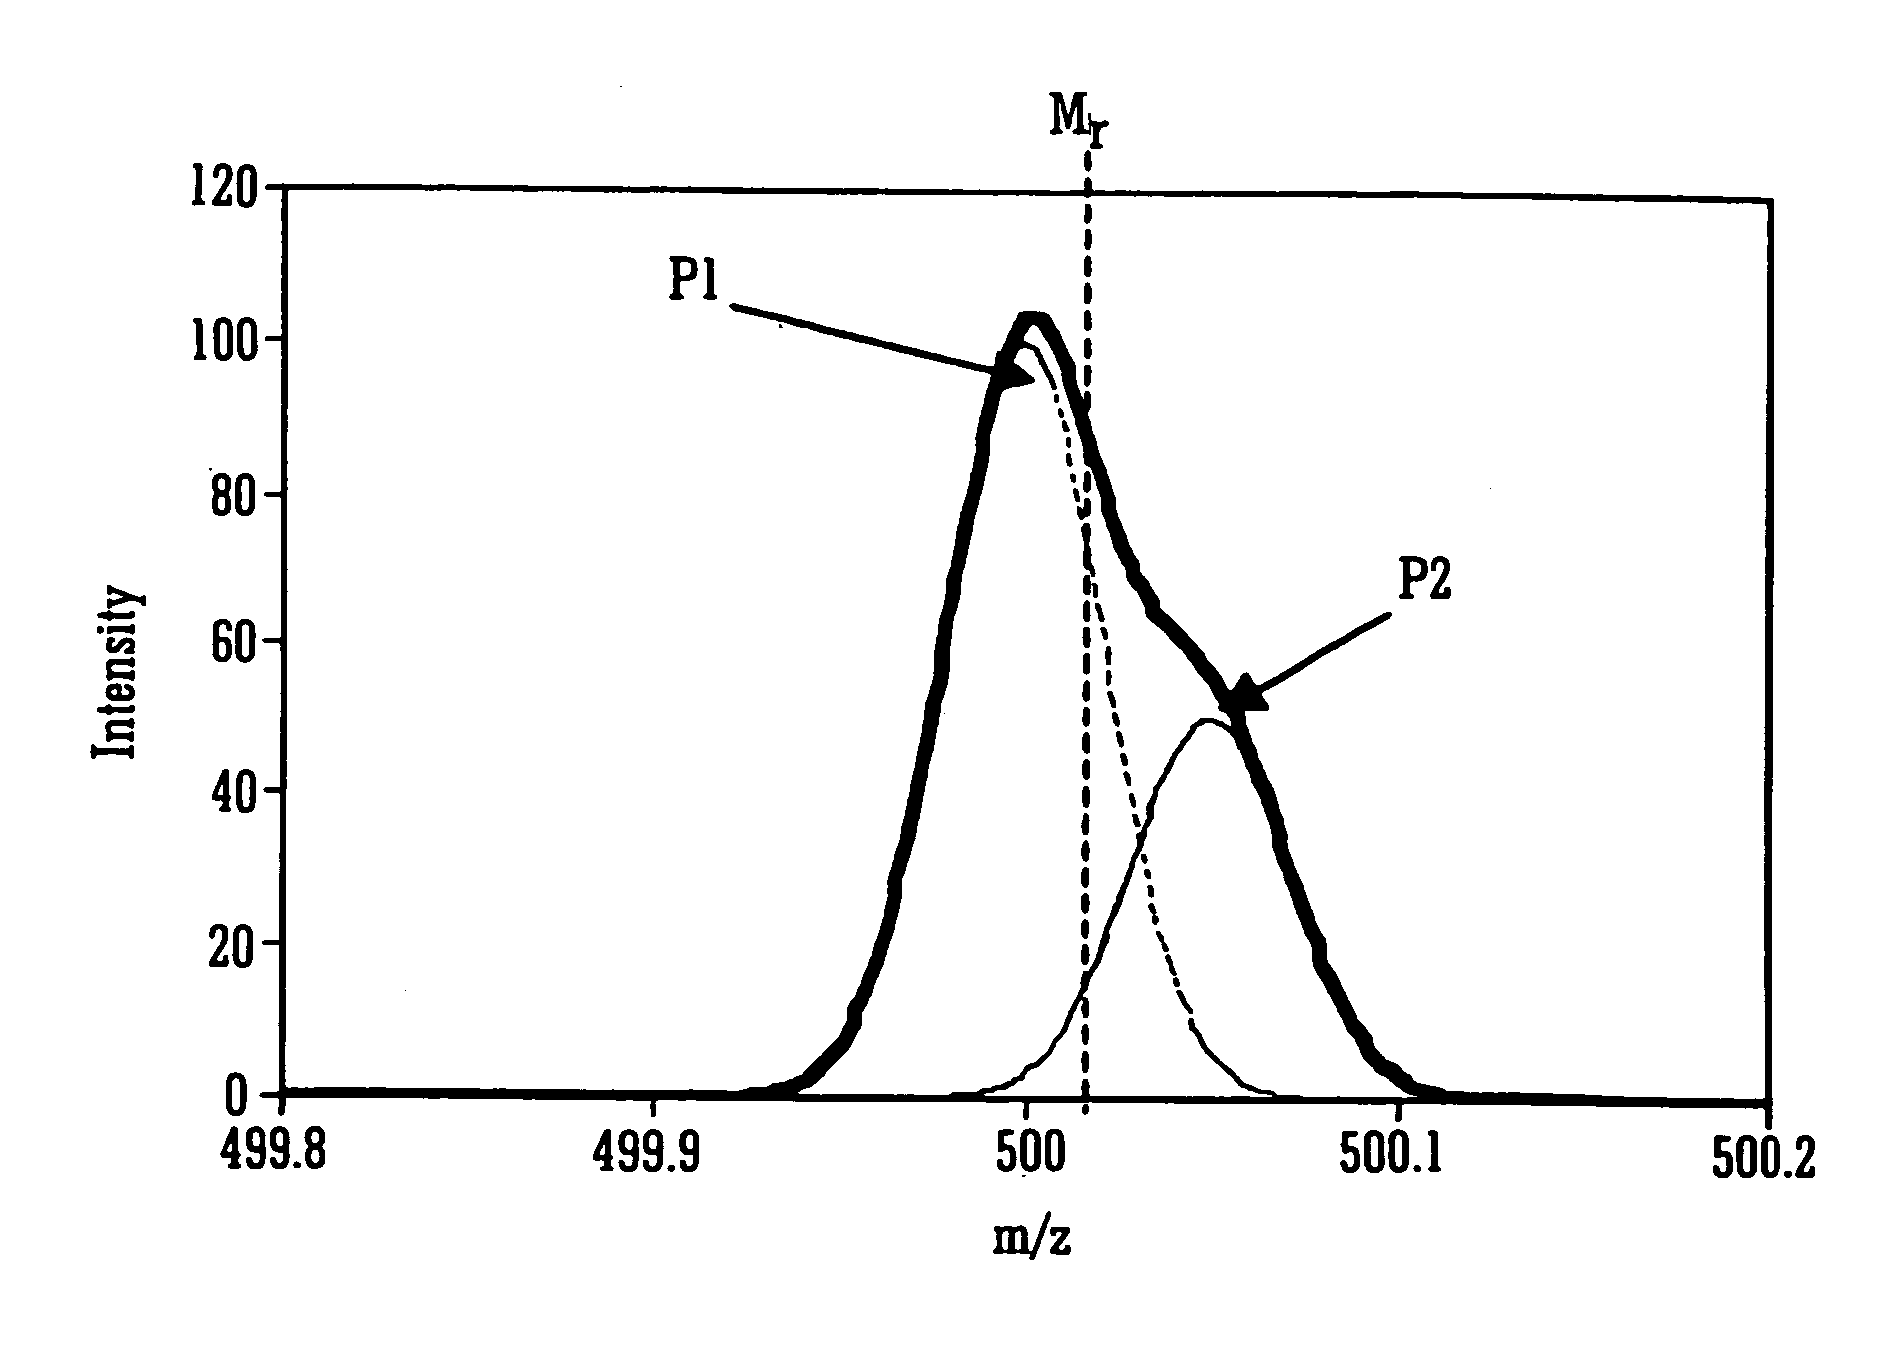
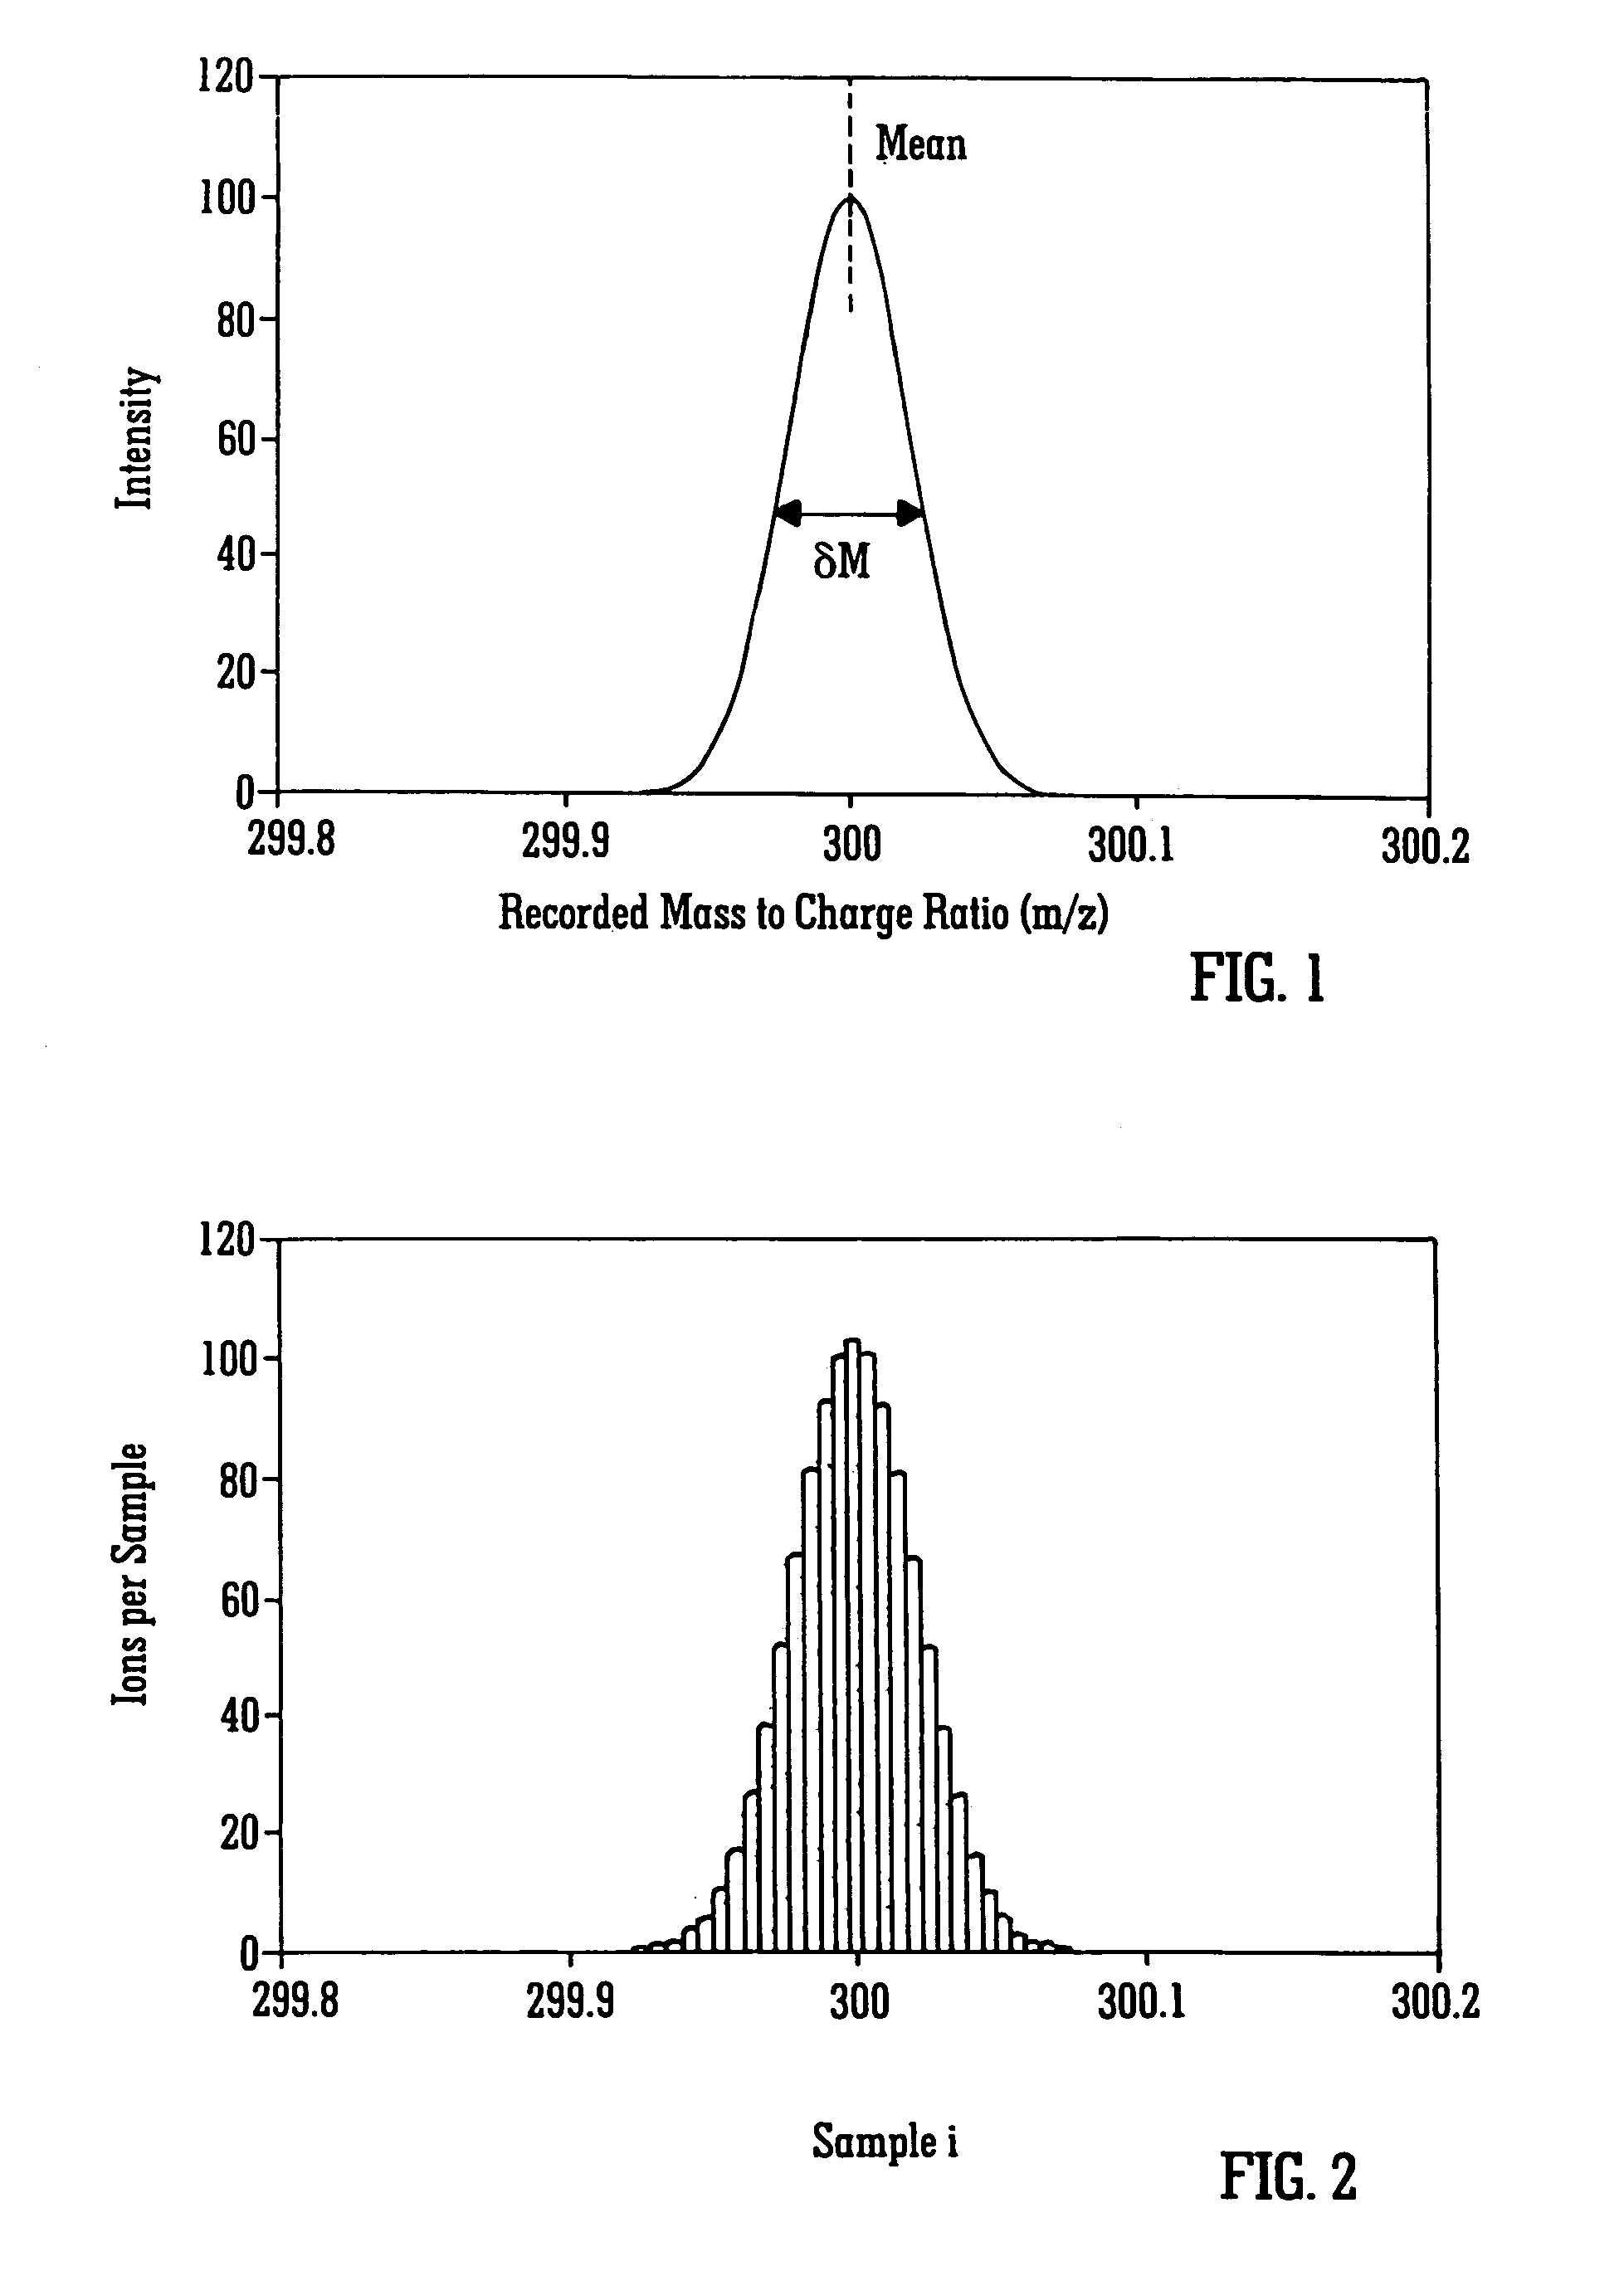
A mass spectrometer is disclosed wherein the experimentally determined mass to charge ratios of ions are reported together with an error band for each mass to charge ratio determination. The error band may, for example, reflect a 95% probability or confidence that the real, true, actual or accepted mass to charge ratio of the ion lies within the error band. By accurately determining the error band the possible candidate ions in a database can be accurately restricted whilst also guarding against over restriction.
Owner:MICROMASS UK LTD
Wind power probability forecasting method based on numerical weather forecasting ensemble forecasting results
InactiveCN103530527ALow running costImprove economySpecial data processing applicationsNumerical weather predictionClassification methods
The invention provides a wind power probability forecasting method based on numerical weather forecasting ensemble forecasting results. Numerical weather forecasting serves as the foundation, basic input data are provided for short-period wind power forecasting through a numerical weather forecasting ensemble forecasting technology, and a short-period forecasting model is established for each ensemble member to obtain a plurality of groups of forecasting results. For the obtained plurality of groups of forecasting results, and different characteristic forecast errors are classified through an ensemble forecasting configuration characteristic classification method and a forecasting power level classification method to obtain future forecast error bands under certain confidence level. According to the wind power probability forecasting method, under the same confidence level, the error band section is narrower, and for power grids containing large-scale wind power integration, under the condition of the same safety margin, the power grid operation cost can be effectively reduced, and the power grid operation economical property can be improved.


Owner:STATE GRID CORP OF CHINA +3
Fast model predictive pulse pattern control
ActiveUS20160276919A1Improve performanceReduce Harmonic DistortionAc-dc conversion without reversalPulse shapingMode controlEngineering
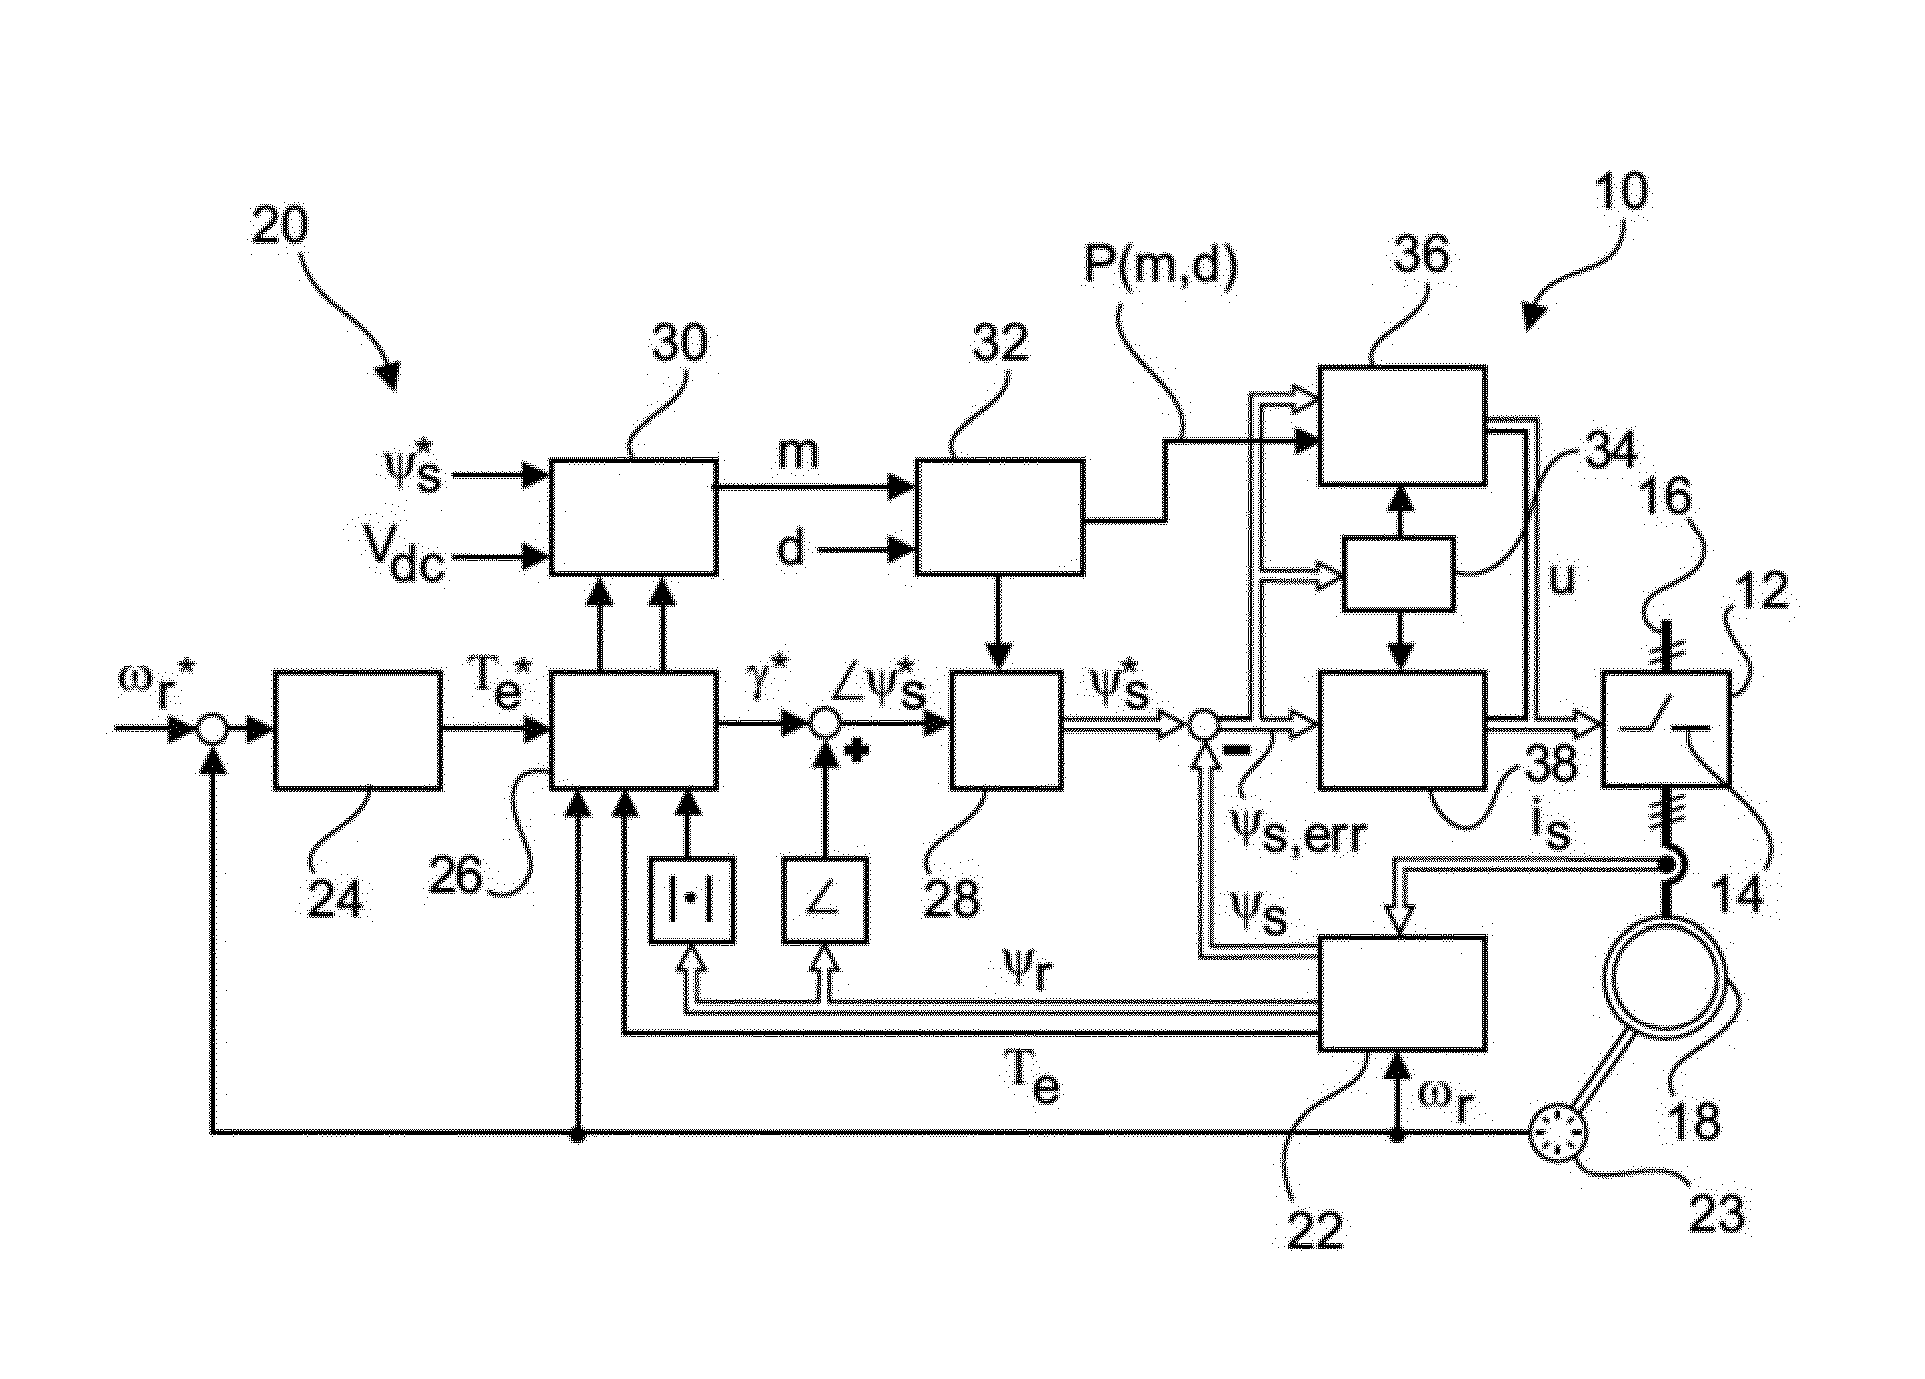
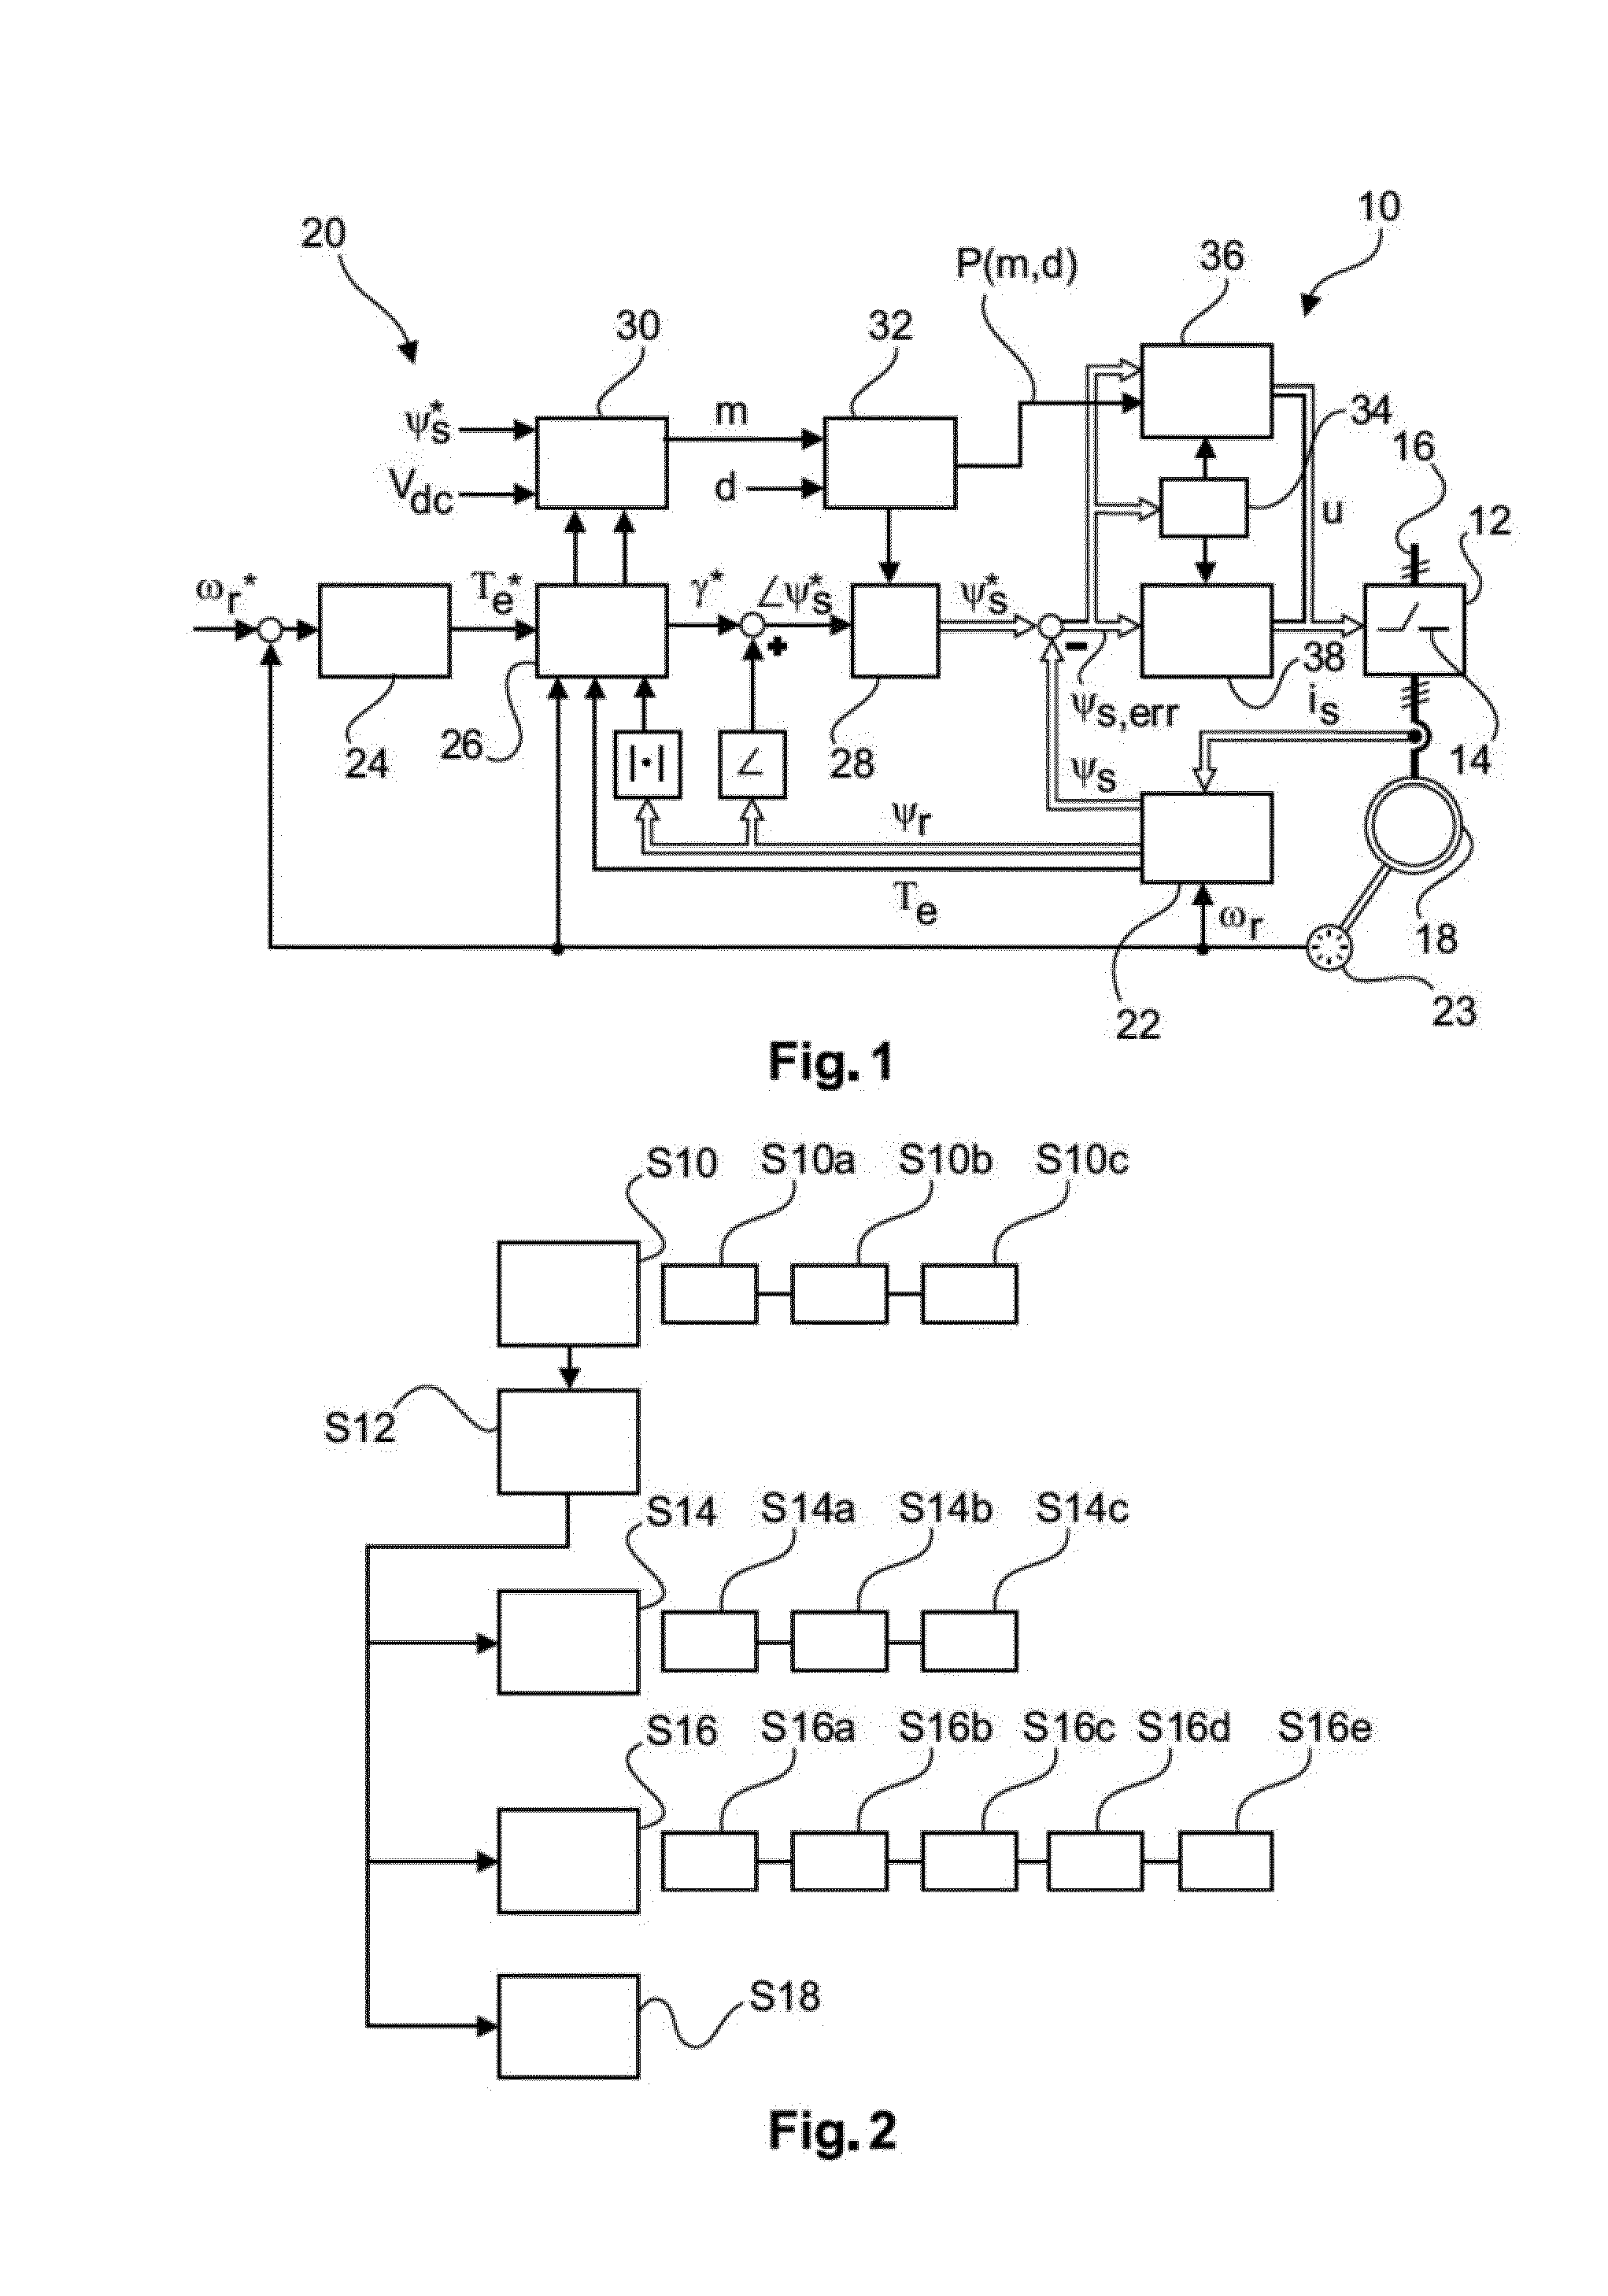
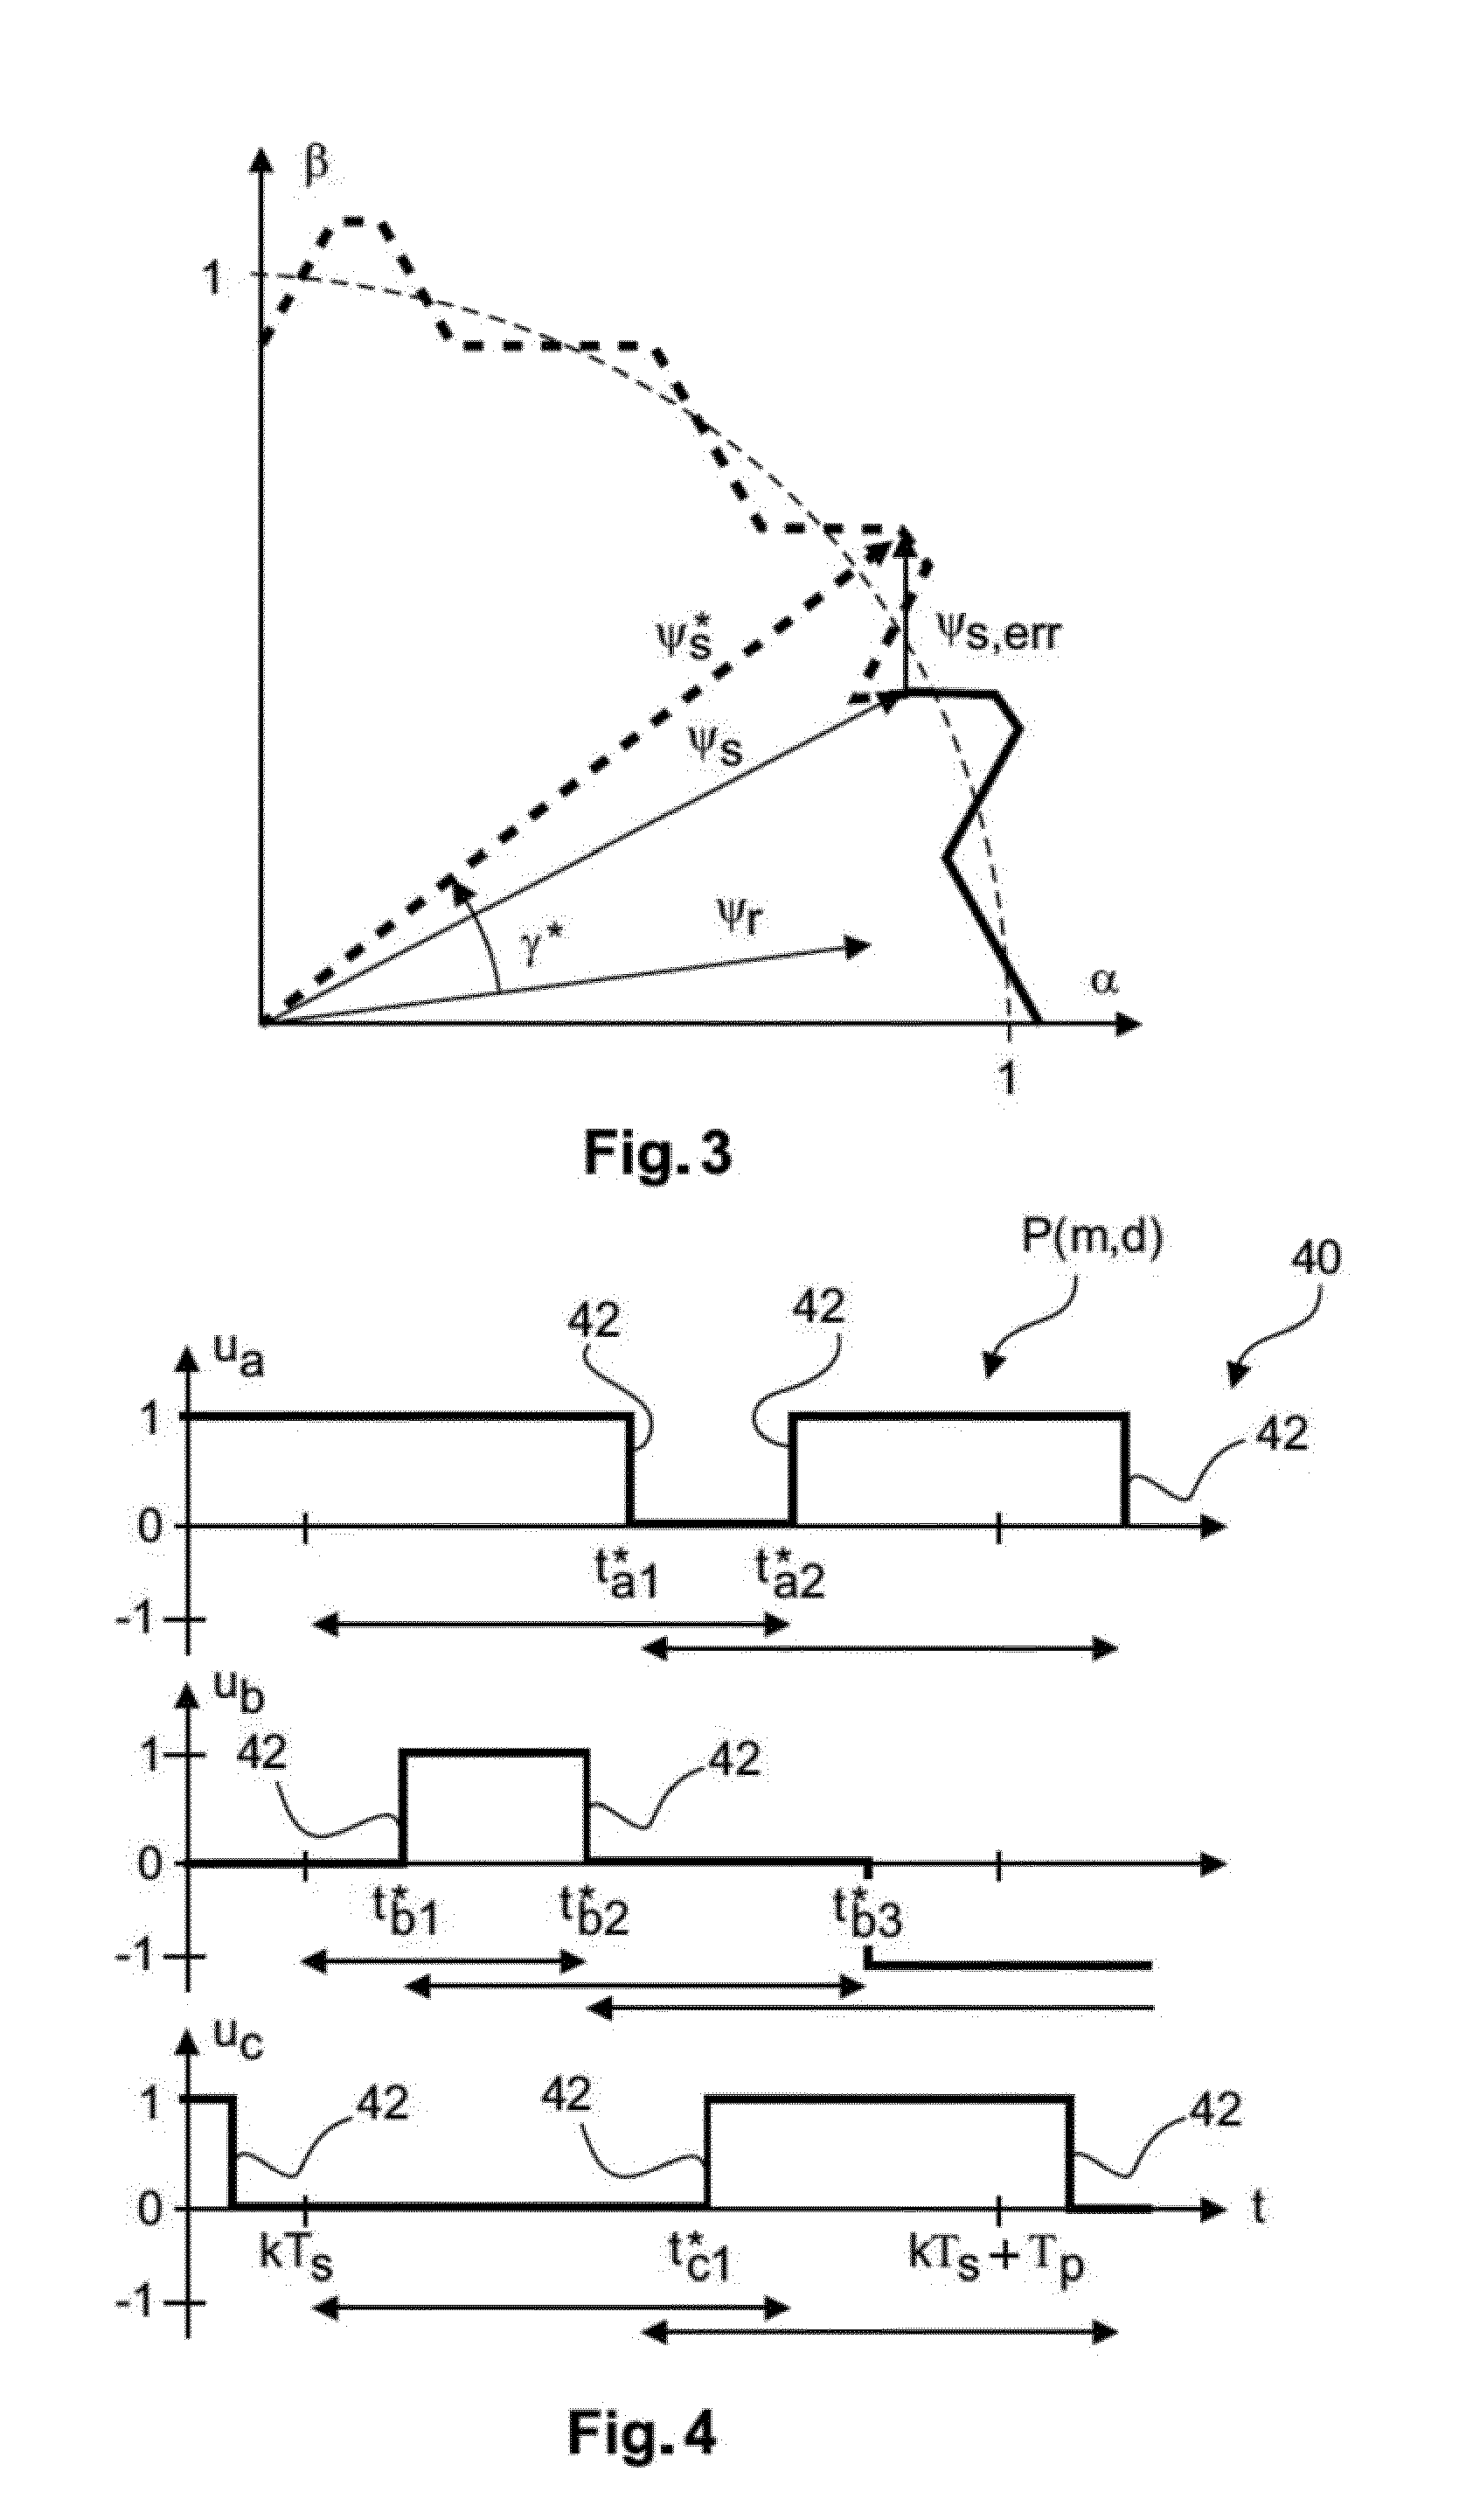
A method for controlling an electrical converter comprises the acts of determining an error value based on a difference between an estimated output value and a reference output value, the estimated output value being based on measurements in the electrical converter; comparing the error value with an error band and in the case of the error value exceeds the error band, controlling the electrical converter by switching to a different control scheme. The converter is controlled with the modified pre-calculated switching by determining a pre-calculated switching sequence for the converter based on an actual state of the electrical converter, the switching sequence comprising a sequence of switching transitions of the converter; modifying the pre-calculated switching sequence by modifying transition times of switching transitions of the pre-calculated switching sequence, such that the error value is minimized; and applying at least a part of the modified switching sequence to the electrical converter.
Owner:ABB (SCHWEIZ) AG
Surface shape detection device and surface shape detection method
ActiveCN110514142ASimplify testing proceduresGuaranteed detection accuracyUsing optical meansLaser interferenceLow frequency
The invention discloses a surface shape detection device and a surface shape detection method that a phase bending surface shape detection method and a laser interference surface shape detection method are combined; the surface shape detection device comprises an imaging unit, a light path adjusting unit, a reference mirror group, a laser interference illumination unit and a phase bending projection unit; the phase bending projection unit and the reference mirror group have the conjugation relationship; and the light of a pattern projected by the phase bending projection unit reaches a surfaceto be detected after passing through the reference mirror group. According to the surface shape detection device and the surface shape detection method provided by the invention, while the detectionprecision of the laser interference detection method is kept, the dynamic range is enlarged; the error band coverage is wide; detection from a low-frequency surface shape to medium-high frequency error can be carried out; full-aperture detection can be rapidly completed without scanning; an extra complex posture calibration process is not required in the system; and posture adjustment of the detection system can be completed based on laser spot alignment of a laser interference light path itself.
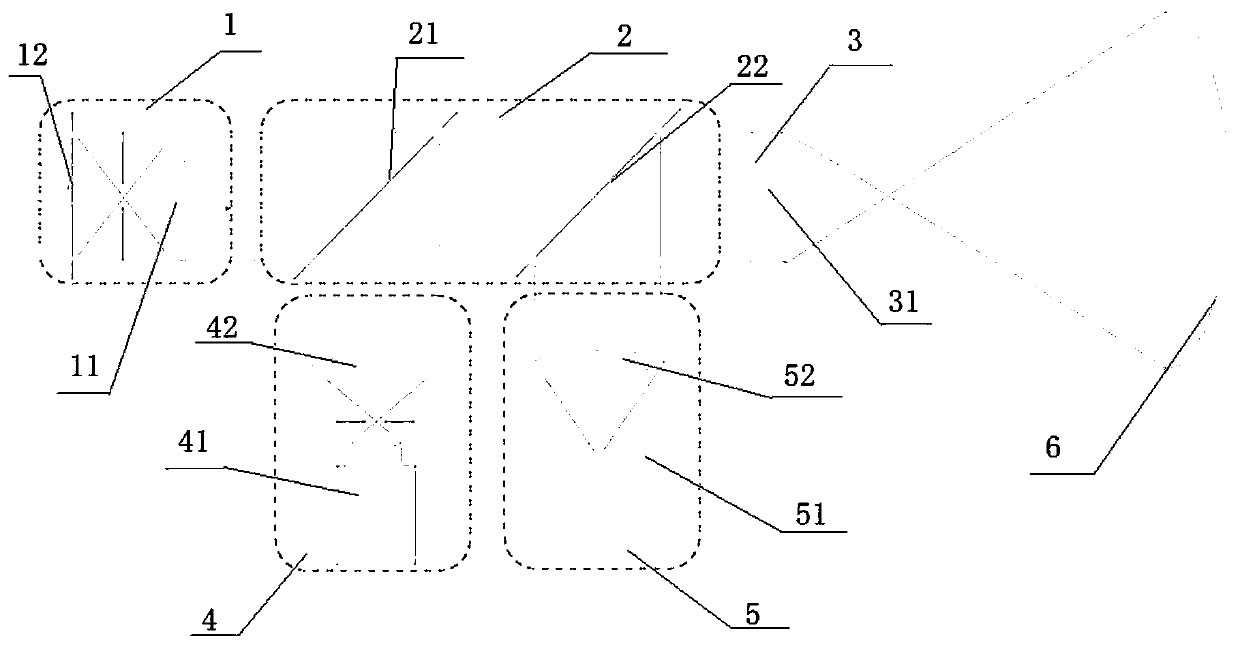
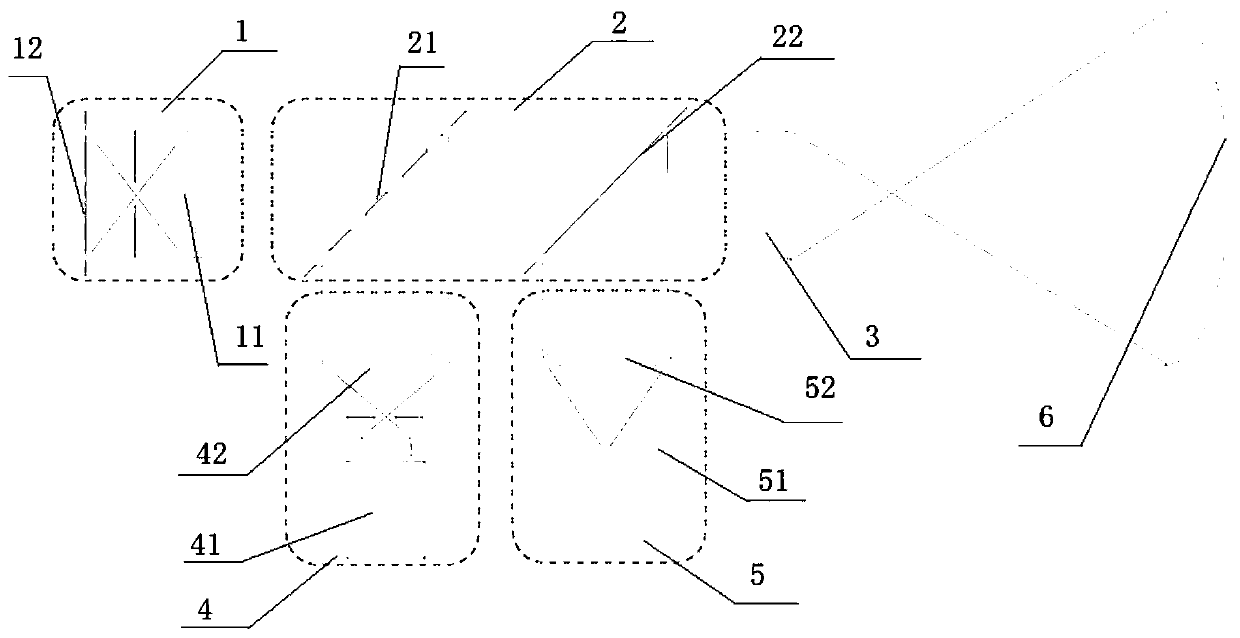
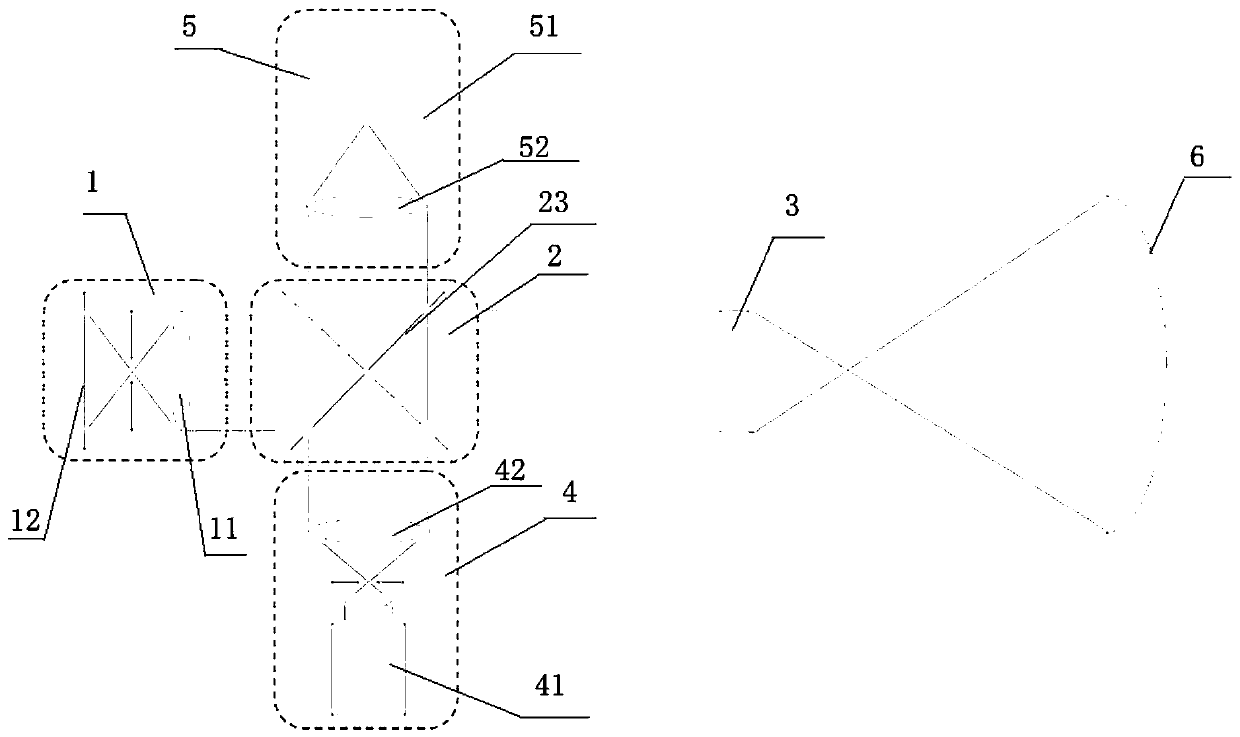
Owner:CHANGCHUN INST OF OPTICS FINE MECHANICS & PHYSICS CHINESE ACAD OF SCI
Rotary hot spare dispatching method in construction of intelligent power grid on basis of relevance vector machine
InactiveCN102709926AMeet the needs of safe and efficient operationMeet the goals of the constructionPower oscillations reduction/preventionElectric power systemNew energy
The invention discloses a rotary hot spare dispatching method in the construction of an intelligent power grid on the basis of a relevance vector machine. The invention relates to the rotary hot spare dispatching method in the construction process of the intelligent power grid on the basis of the relevance vector machine and aims to solve the problem that a rotary hot spare is difficult to set for a new energy resource power system to stabilize the power fluctuation of a wind power connected grid, wherein the new energy resources comprise scale wind power and the like. An initialization setting result is transferred into a wind power relevance vector machine forecasting system; a wind power station wind-power acquisition module acquires a measurement value of a wind power of a wind power station in real time and transfers data into the wind power relevance vector machine forecasting system after carrying out data preprocessing; the wind power relevance vector machine forecasting system receives the data and carries out forecasting on the wind power at the moment in the future so as to obtain a forecasting result, i.e. an error band of the wind power value at the moment in the future and the wind power; and the obtained forecasting value and error band are sent into a dispatching controller, wherein the forecasting value is a power generation plan of the wind power station in the future and the power range represented by the error band is rotary hot spare distributed to the wind power station. The rotary hot spare dispatching method is used in the construction of the intelligent power grid.


Owner:HARBIN INST OF TECH
Method for estimating uncertainty of wind speed fluctuation based on effective turbulence intensity instantaneous model
ActiveCN103678940AHigh precisionAvoid Redundant Spinning Hot StandbySpecial data processing applicationsWavelet decompositionPower grid
The invention relates to a method for estimating wind speed fluctuation uncertainty based on an effective turbulence intensity instantaneous model, and solves the problems that error bands in the same width are given in an area with low wind speed and an area with high wind speed and an overlarge prediction error exists, does not accord with actual conditions and is not favorable for making a reasonable scheduling plane for a power grid in a method for estimating the uncertainty of wind speed fluctuation based on the current theoretical model. Instantaneous standard deviation of turbulence residual difference is obtained through a Mallat wavelet decomposition and reconstruction algorithm, and the uncertainty of the wind speed fluctuation is estimated by fitting through the effective turbulence intensity instantaneous model according to average wind speed. The method is used for predicting the power of a wind power plant, so that the reasonable scheduling plant is made for the power grid, spinning reserve is determined, and the operation of the power grid is safely and economically guaranteed.


Owner:HARBIN INST OF TECH
Automatic homeward voyage method for multi-sensor data fusion of unmanned vehicle
PendingCN120669711AVehicle position/course/altitude controlPosition/direction controlSpatial mappingEngineering
The invention relates to the technical field of automatic driving, in particular to an automatic homeward voyage method for multi-sensor data fusion of an unmanned vehicle, which comprises the following steps: acquiring laser radar obstacle points, image edges and attitude data, completing synchronous registration, identifying space mapping, extracting track and boundary trends, screening forward sections, and judging track offset and trafficability. Screening an error band boundary, adjusting a steering instruction, analyzing path overlapping change, and outputting a path keeping label. According to the method, through time synchronization and space registration of various sensor data, high-precision fusion of the data under a unified space-time framework is realized, the reliability of environment perception is improved, accurate mapping of the data in a unified reference coordinate system is ensured, the reliability of path planning and decision making is enhanced, and the optimal advancing direction is determined by combining a homing point; the accuracy of return route planning is improved, the traffic feasibility is dynamically evaluated, the effective error band boundary is screened to improve the safety, and the reliability of the return route is ensured through track stability analysis.

Owner:TIANJIN HUANYU LANTIAN AVIATION TECH CO LTD
Track planning method of concrete distribution robot based on Q learning
ActiveCN113062601AVersatilityGeneralizabilityBuilding material handlingTrajectory planningControl theory
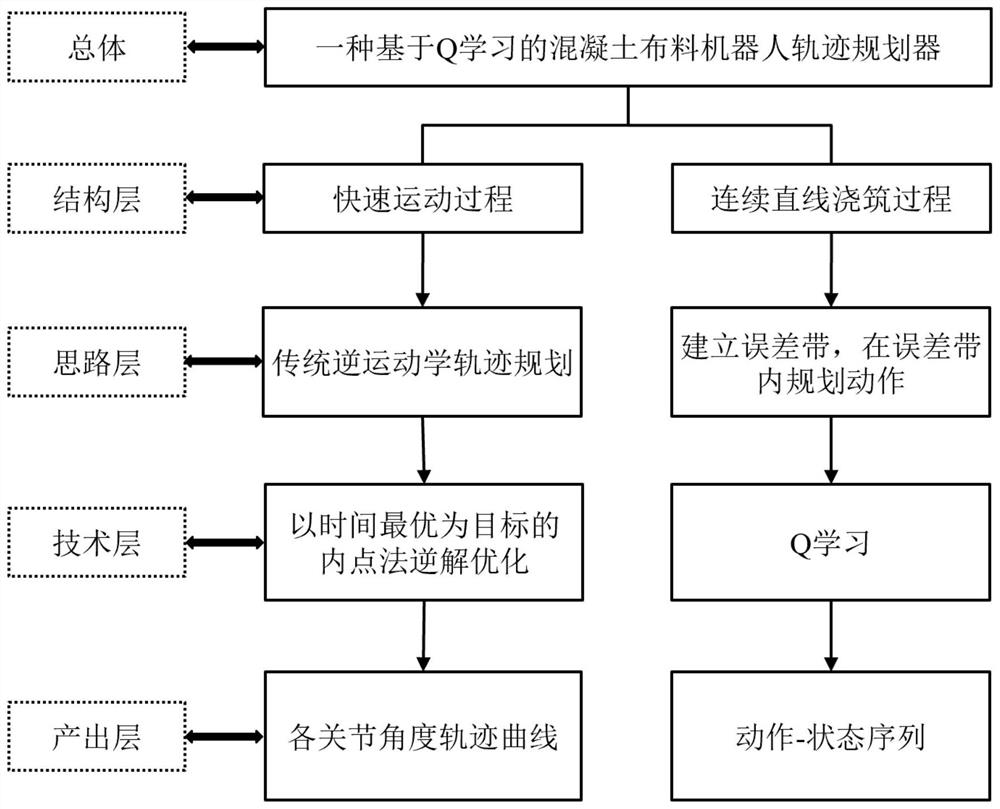
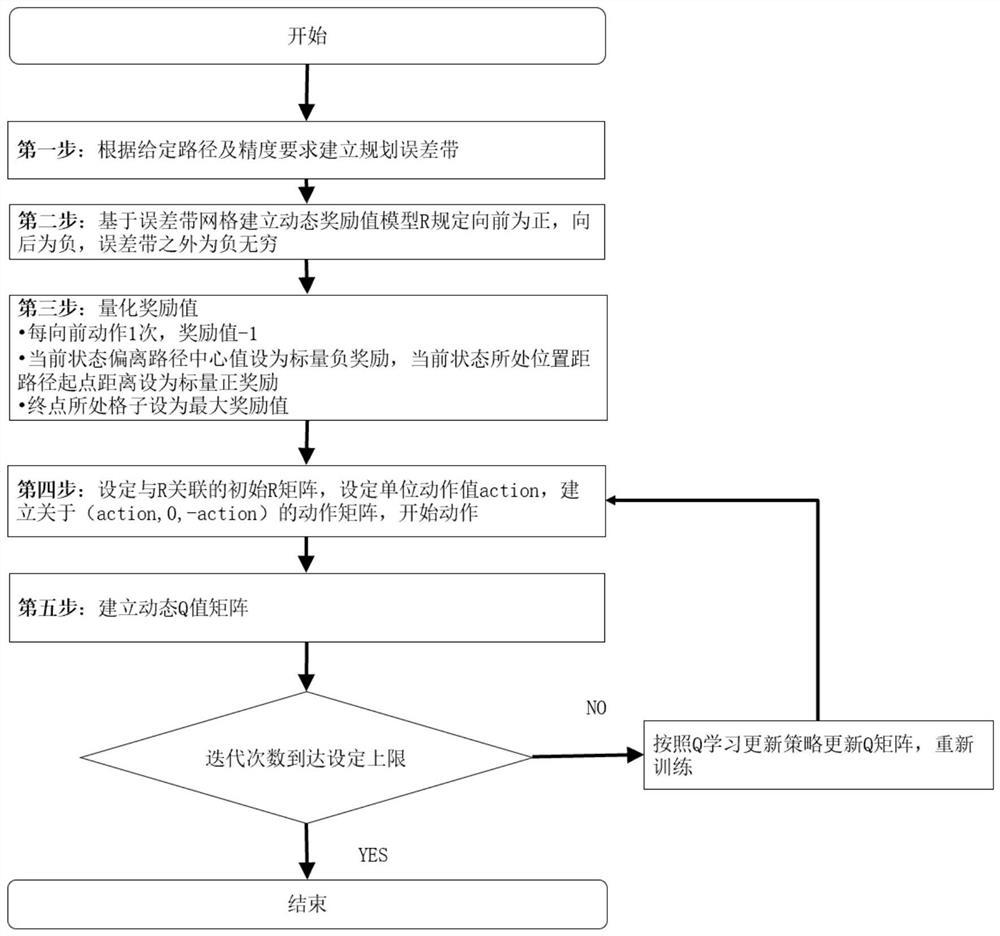
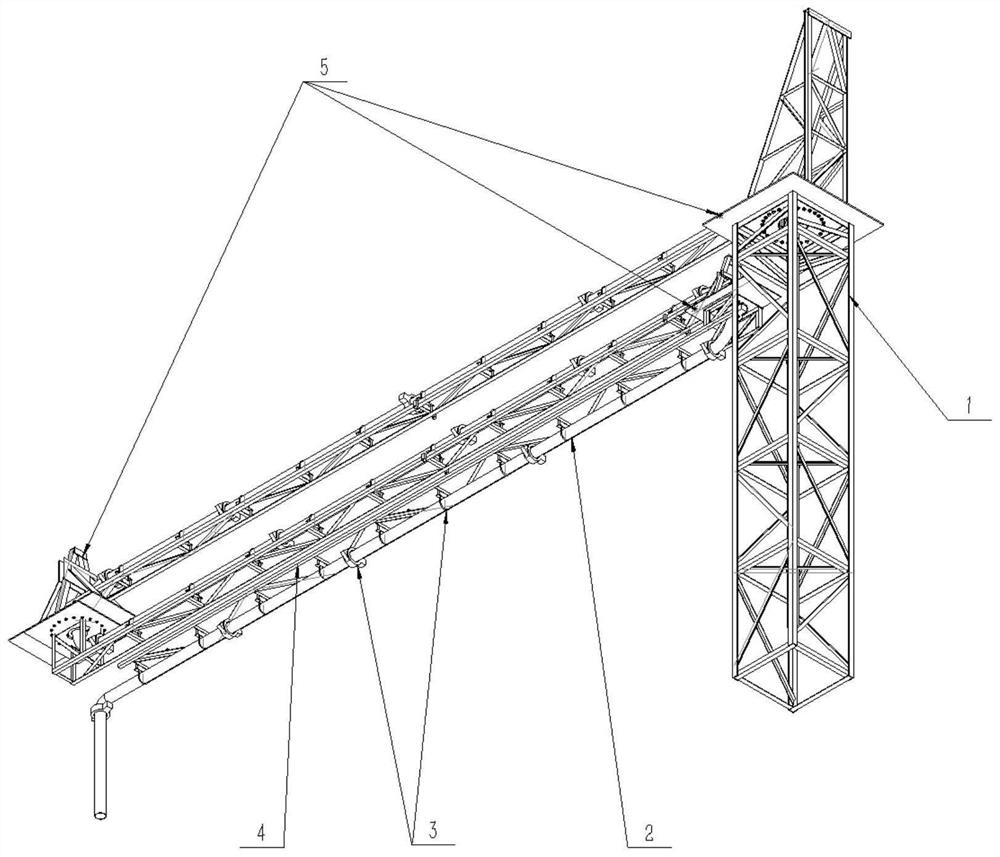
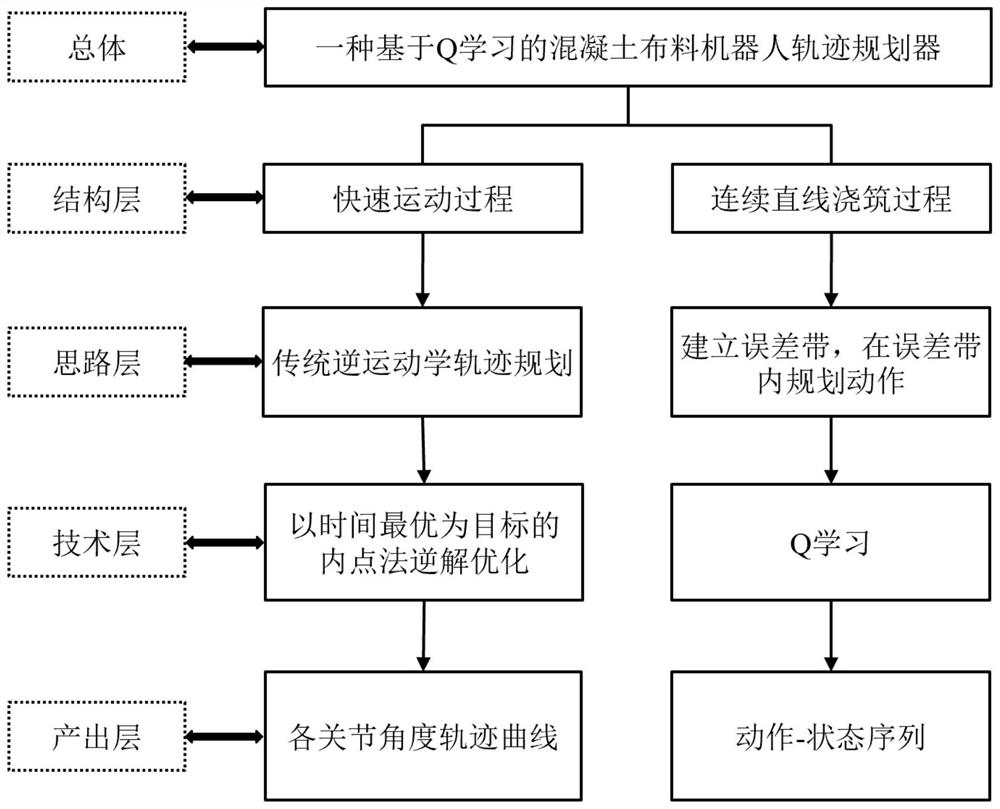
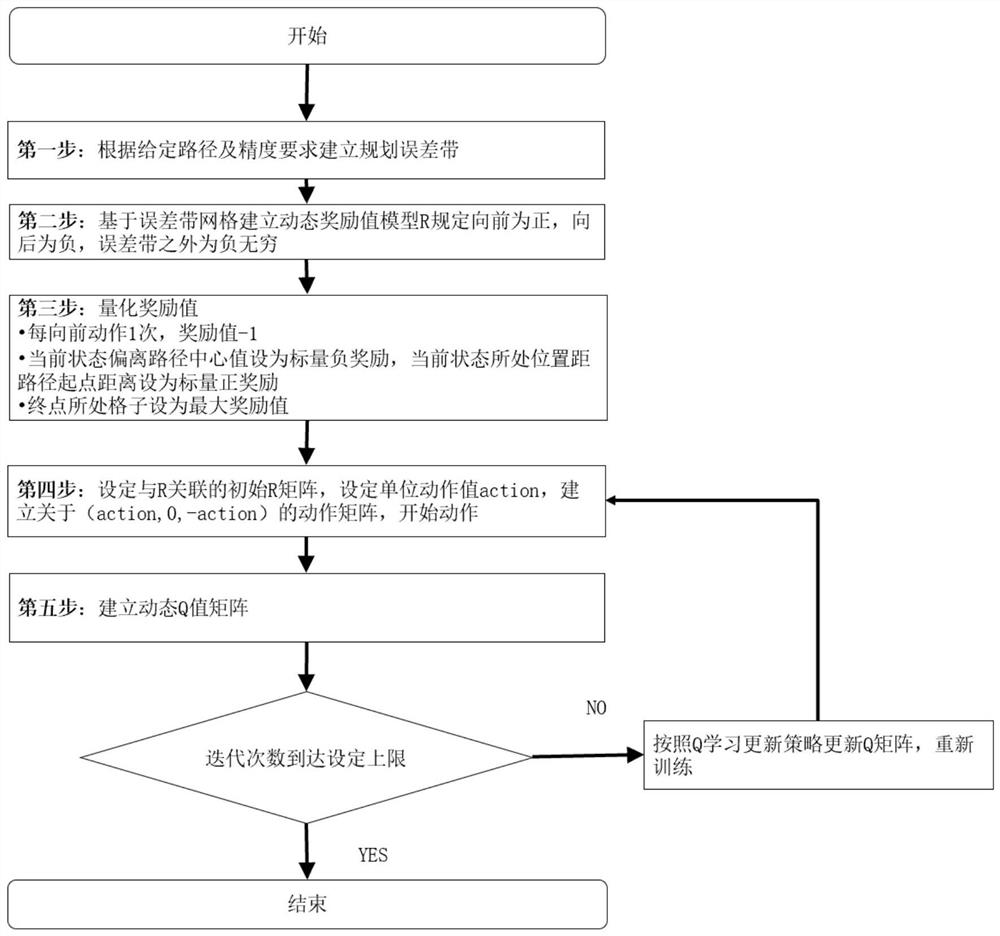
The invention relates to a novel track planning method of an intelligent concrete distribution robot. The track planning method is suitable for autonomous pouring control of the concrete distribution robot and avoids complex inverse kinematics interpolation calculation. The invention belongs to the field of intelligent manufacturing. A universal track planning framework is designed, the universal track planning framework comprises a rapid movement process of the distribution robot from an initial state to a path starting point and from a path end point to the initial state, and a continuous concrete pouring process of the distribution robot from a pouring path starting point to a pouring path end point. In the rapid movement process, a simple interior point method is adopted to carry out inverse solution optimization with time optimization as a target, and a cubic polynomial is adopted to fit a track; in the continuous concrete pouring process, a path needing to be poured at the tail end of the distribution robot forms an error band with a certain area, region division is conducted on the formed path error band through a Q learning algorithm, an award value is given to the divided region according to a pouring target and constraint, Q value training is conducted on a given grid, and finally, an action sequence of all joints of the robot is formed, robot actions are directly obtained, and a complex track planning process based on kinematics inverse solution optimization is avoided.
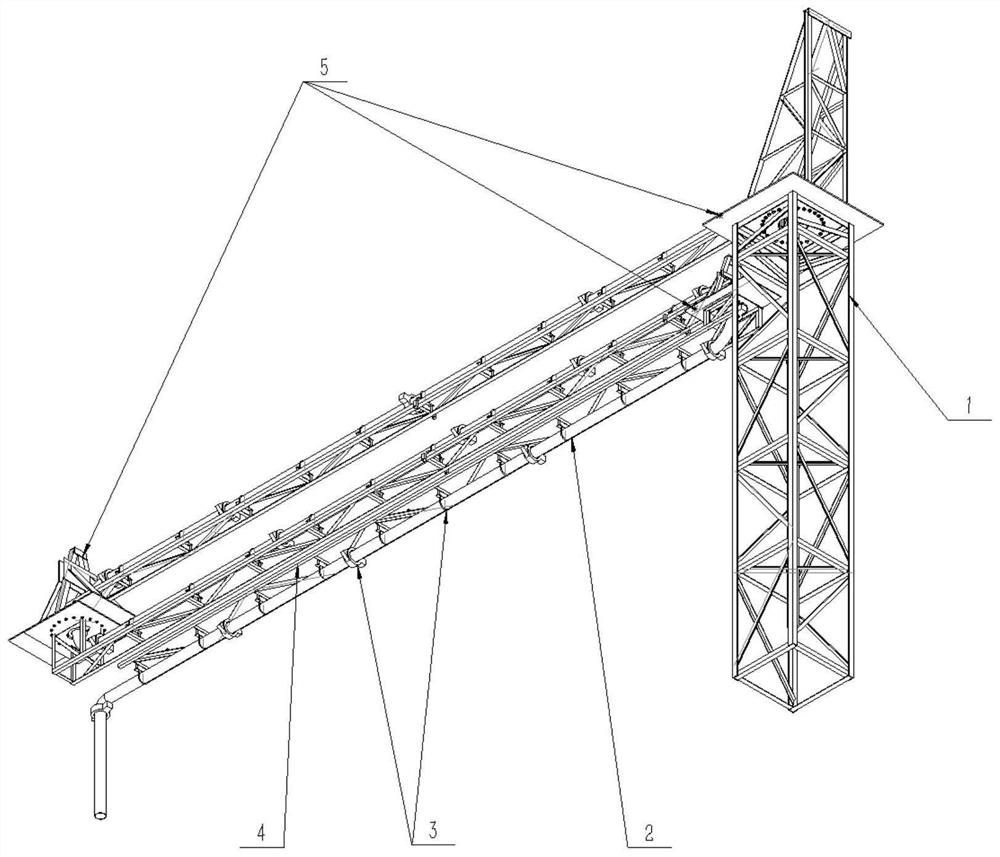
Owner:TONGJI UNIV
Method and apparatus for displaying image signal
ActiveUS8063913B2Reduce colorIncrease in sizeImage enhancementImage analysisMedicineComputer graphics (images)
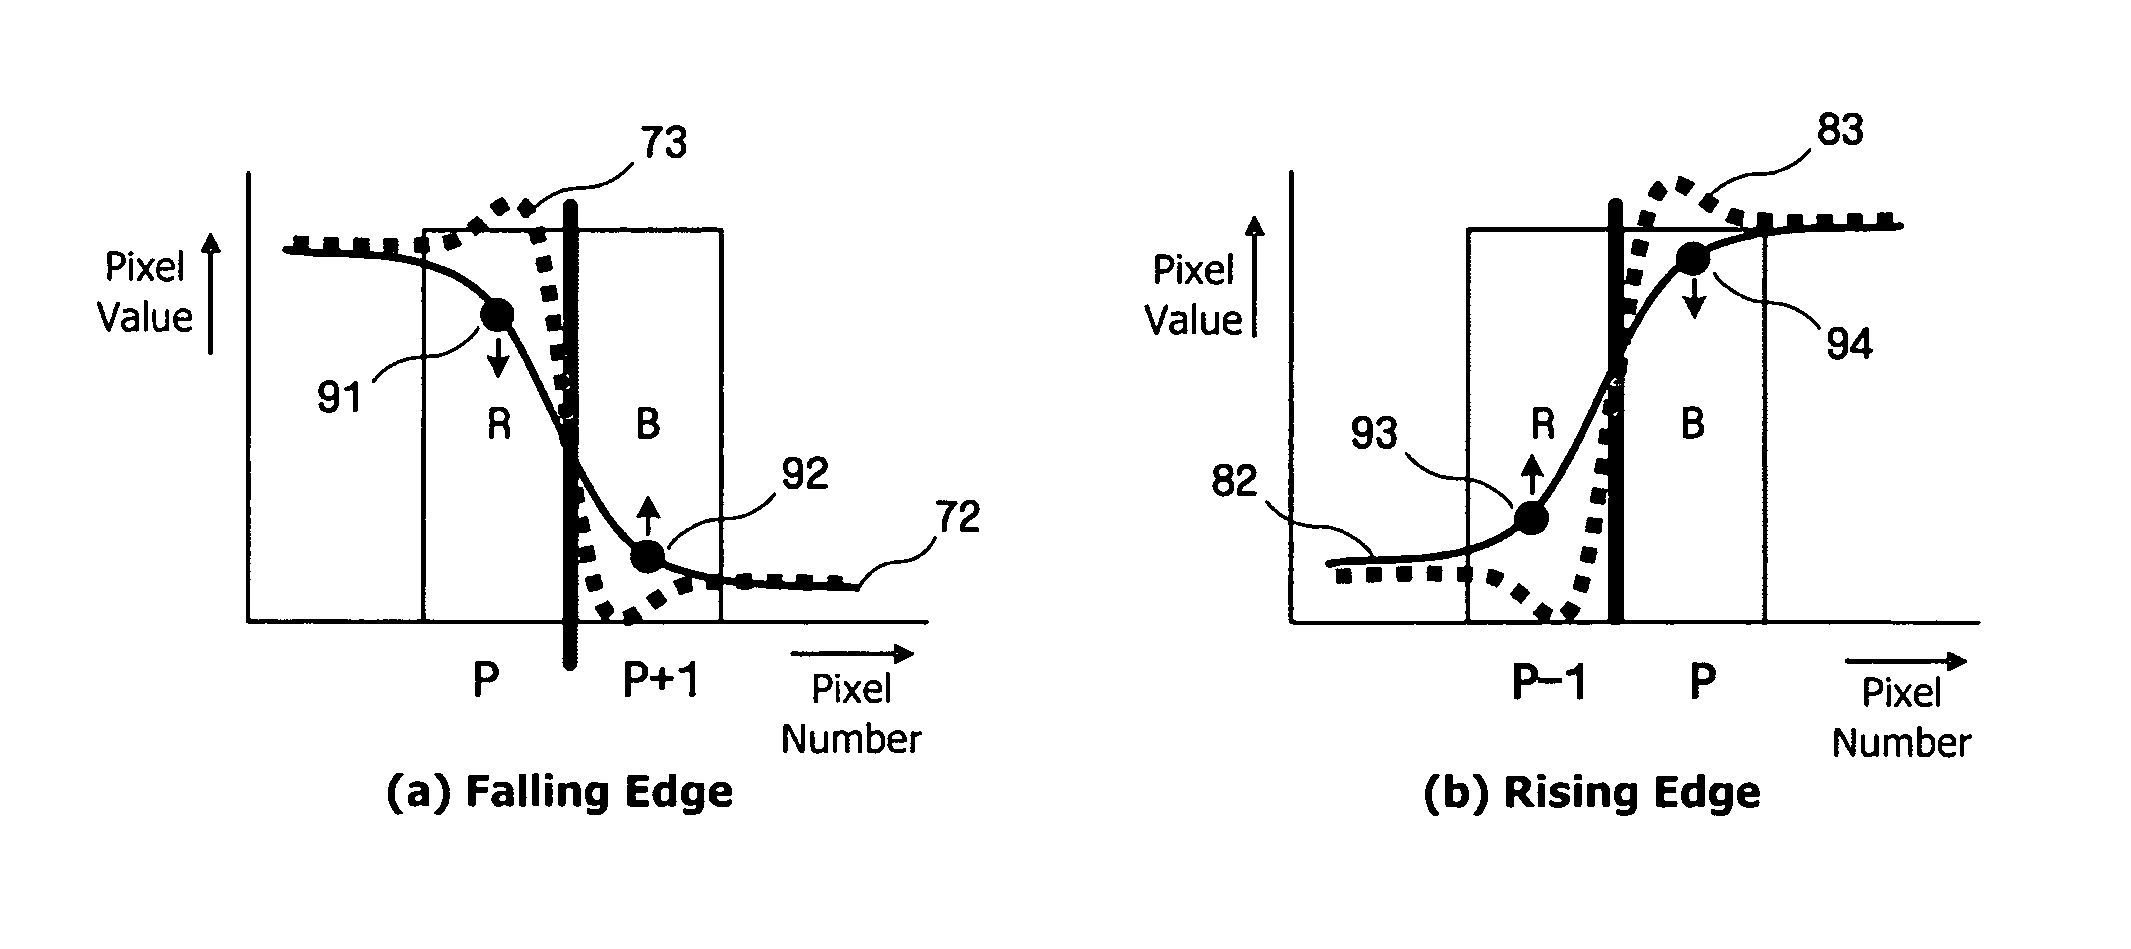
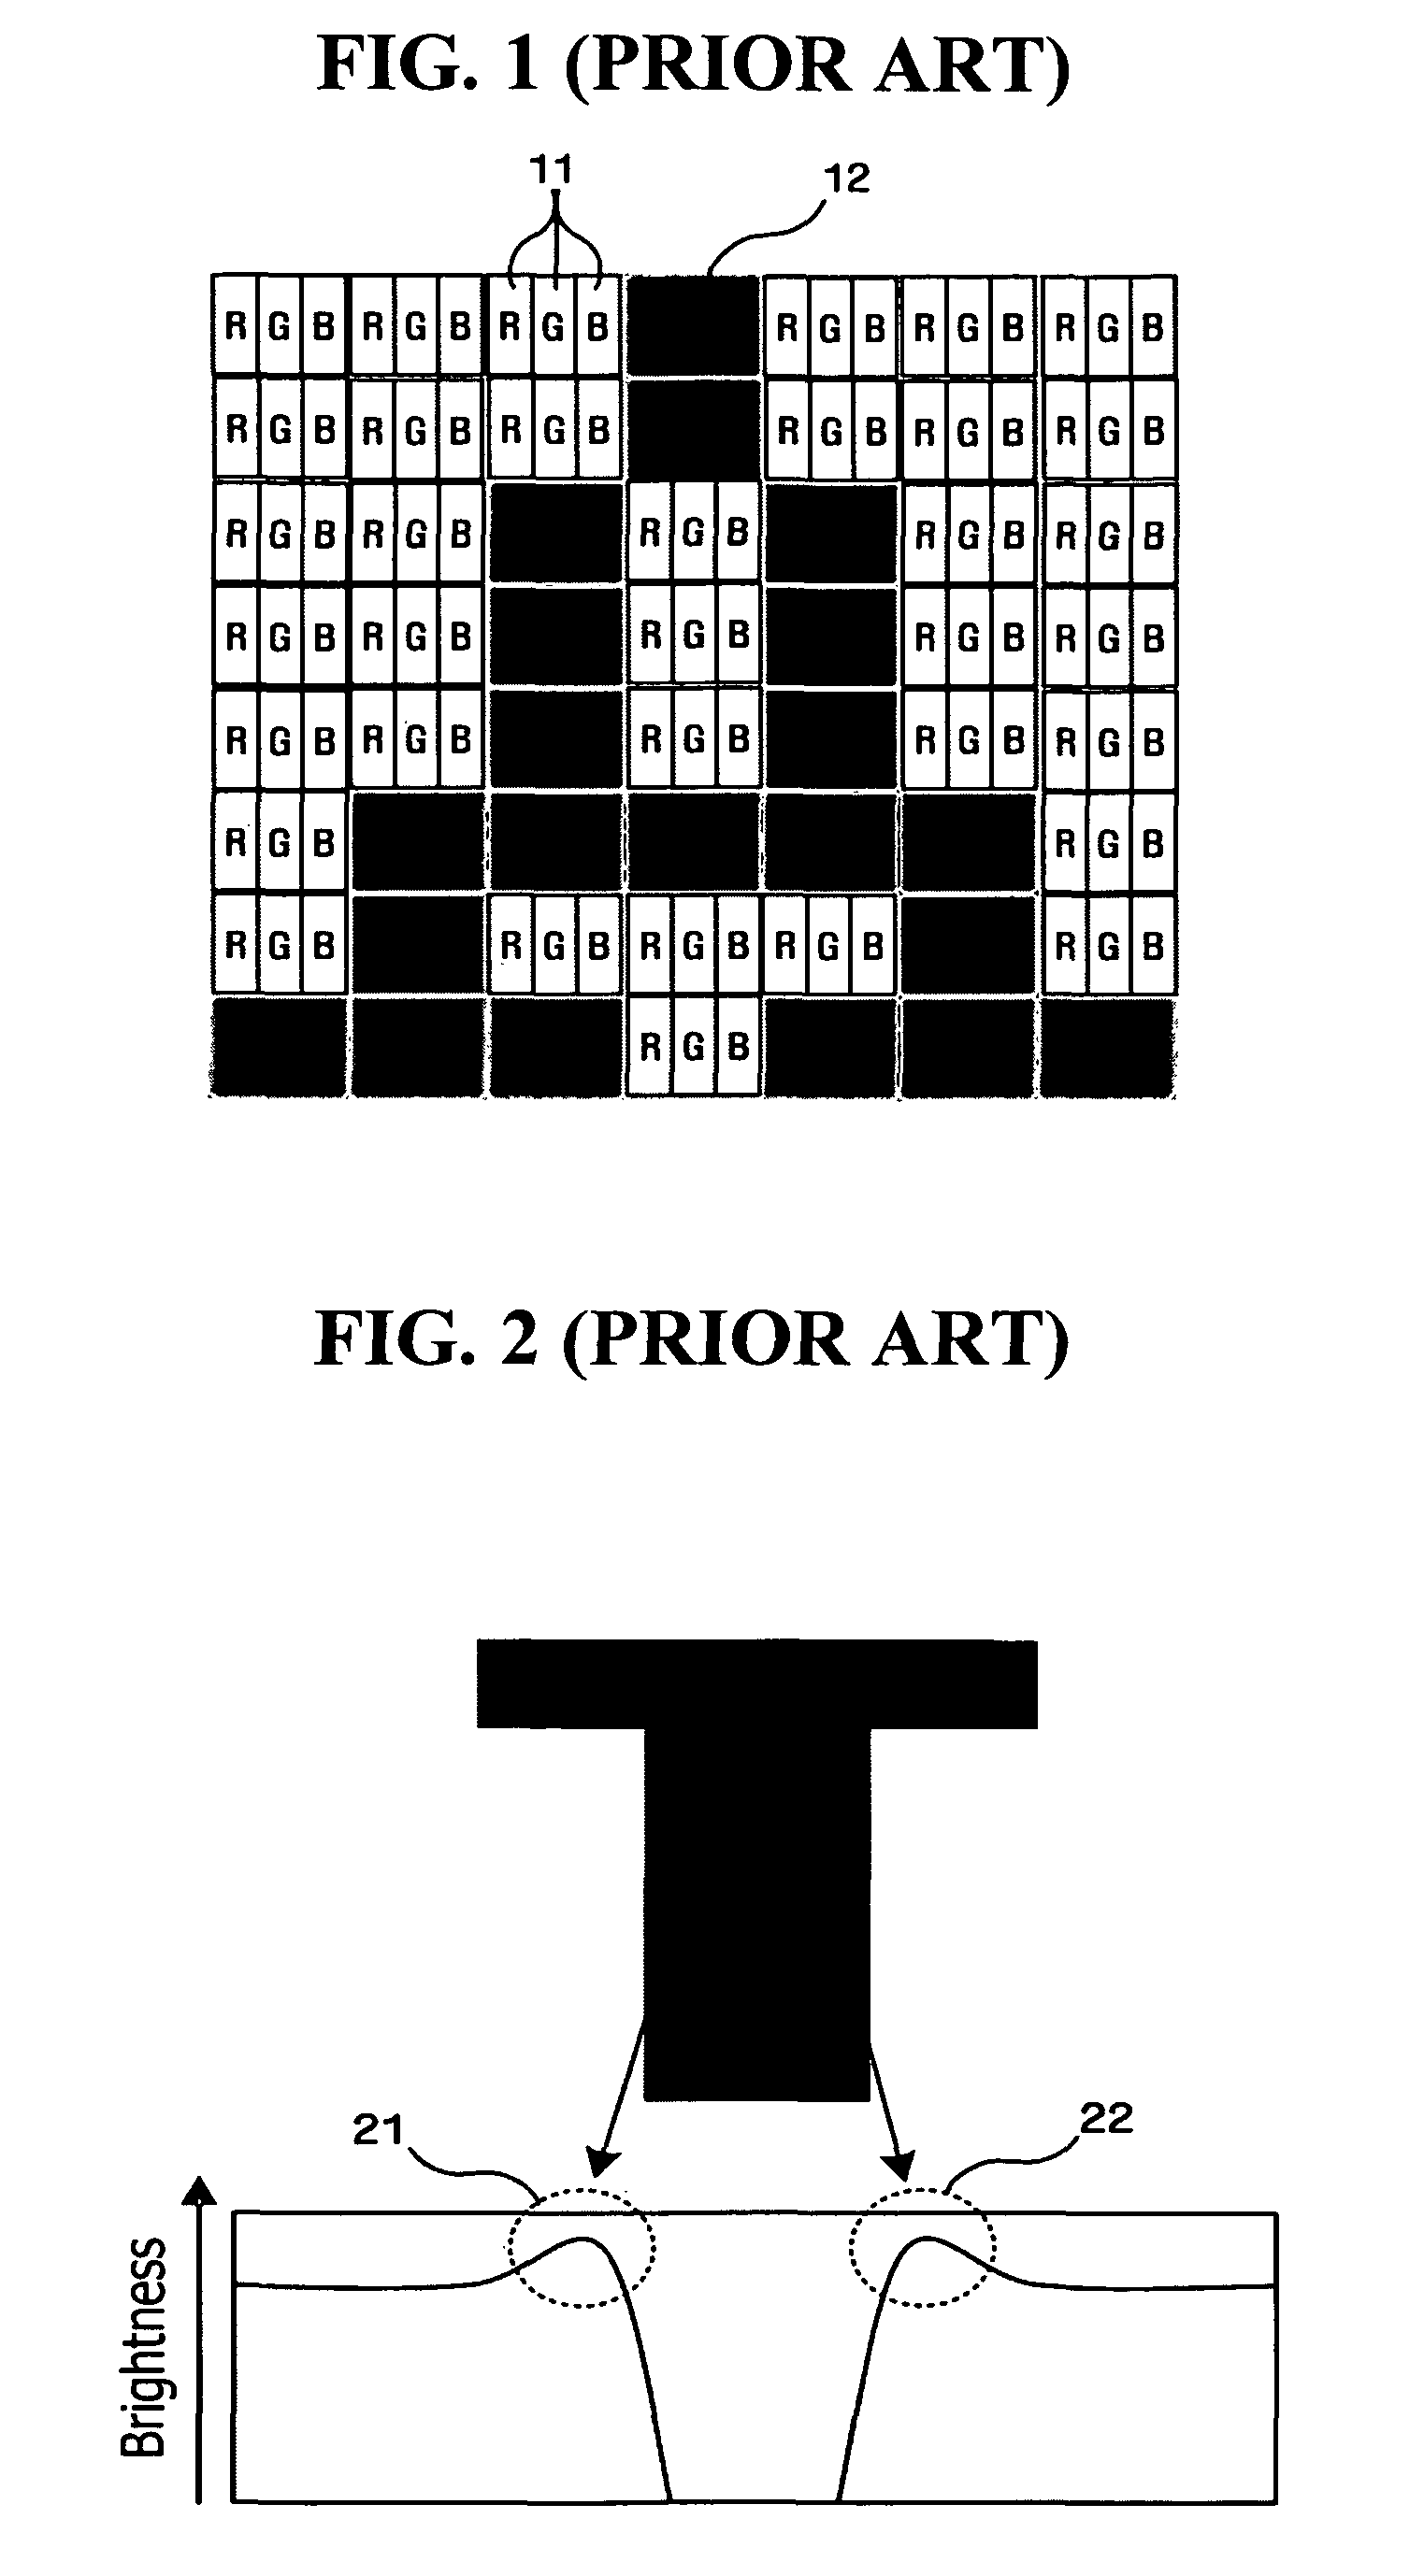
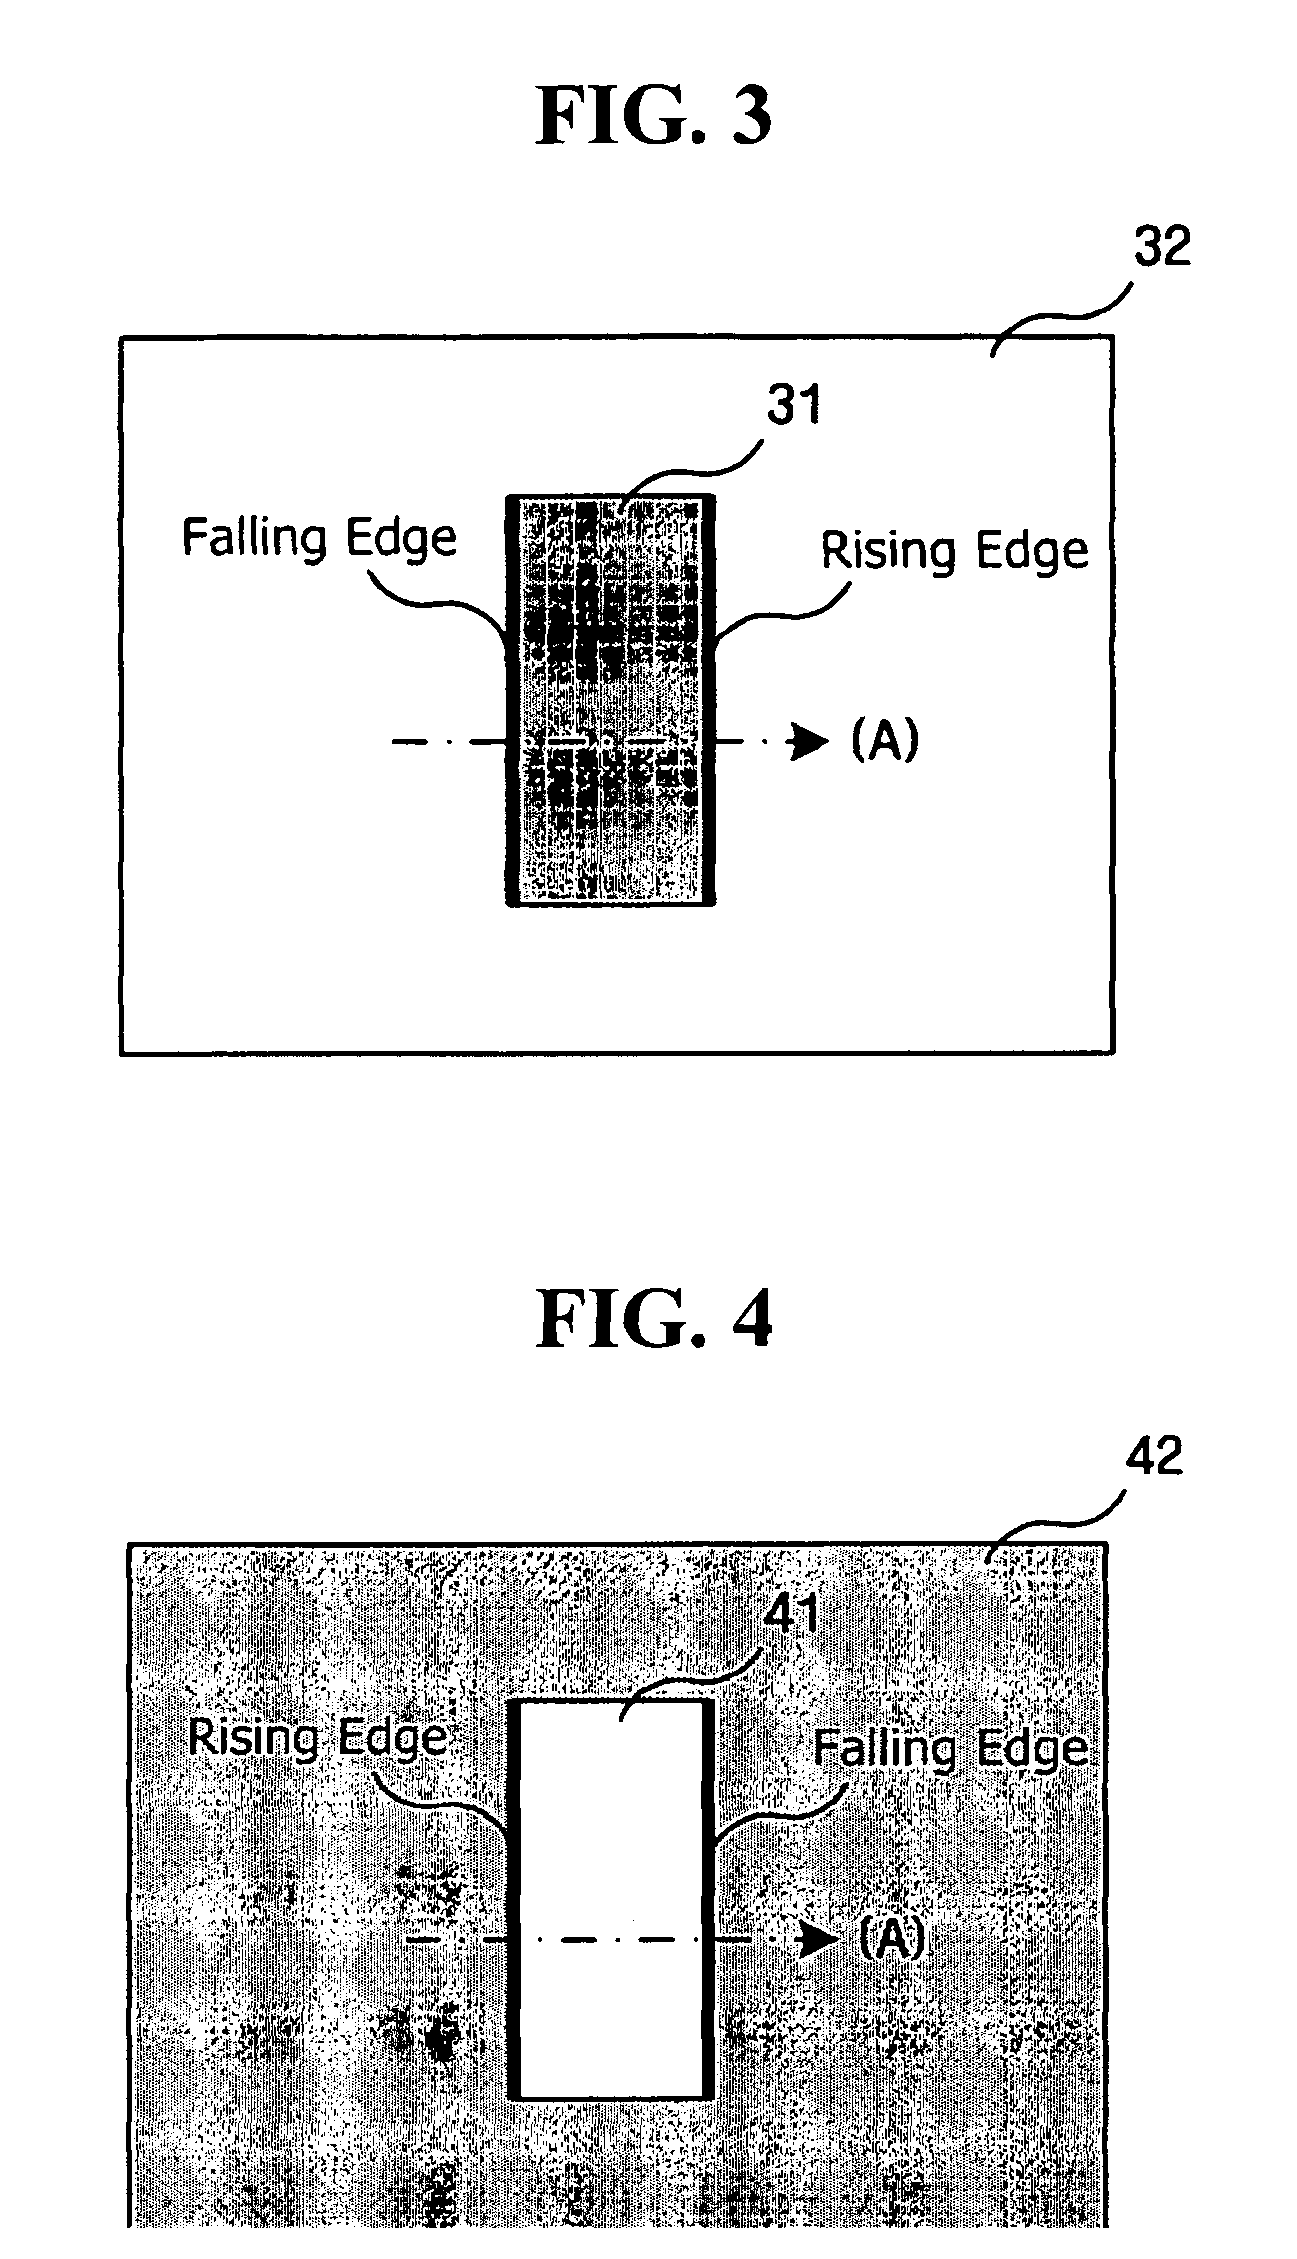
A method and apparatus for reducing color error bands occurring due to the abrupt difference in brightness between sub-pixels. In the method of displaying an image signal of an apparatus for displaying the image signal, the apparatus includes a plurality of pixels each having at least two sub-pixels, and the method includes detecting pixels that belong to an edge of an input image, changing pixel values of the sub-pixels constituting the pixels belonging to the edge, and driving a display in accordance with the new pixel value.
Owner:SAMSUNG ELECTRONICS CO LTD
Synergic control method for power allocation of electric vehicle composite power supply
ActiveCN109617205ASolve technical problems that are difficult to achieve multi-objective controlFast dynamic responseBatteries circuit arrangementsElectric powerHysteresisReference current
The invention discloses a synergic control method for power allocation of an electric vehicle composite power supply. The synergic control method comprises the steps of acquiring a DC bus voltage in real time; making a synergic control strategy according to the DC bus voltage acquired in real time and a DC bus reference voltage, and calculating to obtain a reference current of a hysteresis currentcontroller; acquiring a filtering inductance current in a bidirectional boost-buck converter, generating a switch control signal according to the acquired filtering inductor current and the referencecurrent; and generating a pulse signal to control on / off of a first control switch and a second control switch according to the switch control signal so as to achieve synergic control for power allocation of the composite power supply. With a given error band, the filtering inductor current i<L> is controlled to follow the reference current I<r>, a supercapacitor is controlled to charge and discharge, the output DC bus voltage v<0> is maintained constant, the reference current I<r) of a filtering inductor is obtained according to the synergic control strategy, the DC bus voltage v<0> is optimized, the dynamic response of the supercapacitor is improved, and the optimal power balance is maintained between a storage battery and the supercapacitor.


Owner:JIANGSU UNIV OF TECH
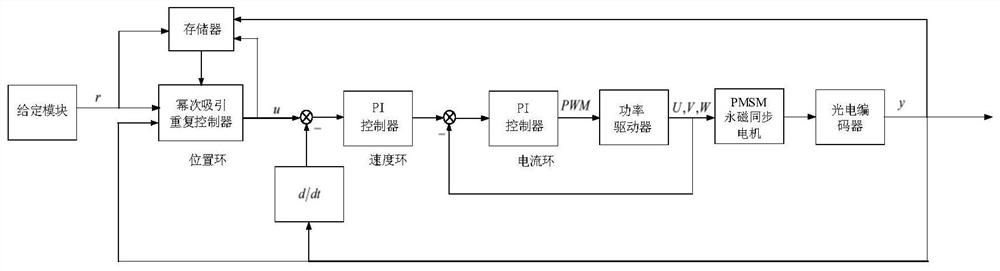
Servo system non-switching attraction repetitive control method adopting equivalent disturbance compensation
InactiveCN110658719APeriodic Interference SuppressionFast convergenceAdaptive controlControl engineeringComputer science
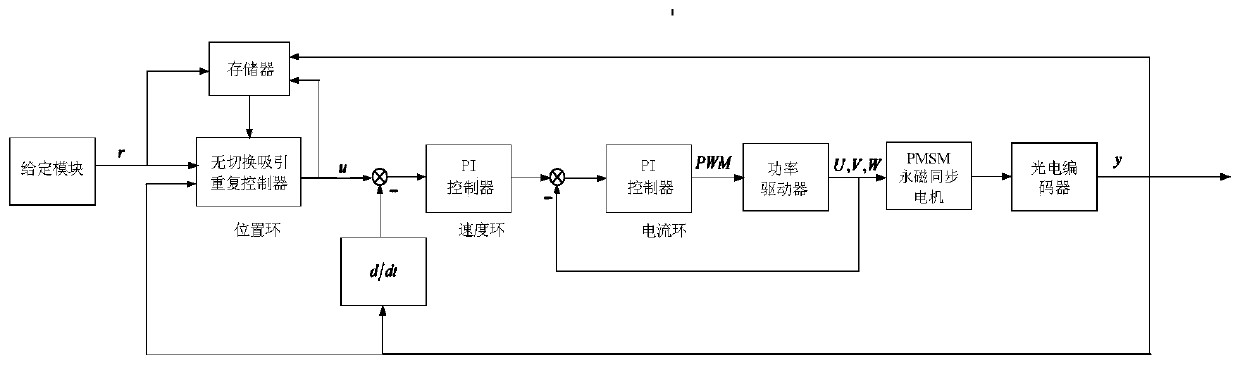
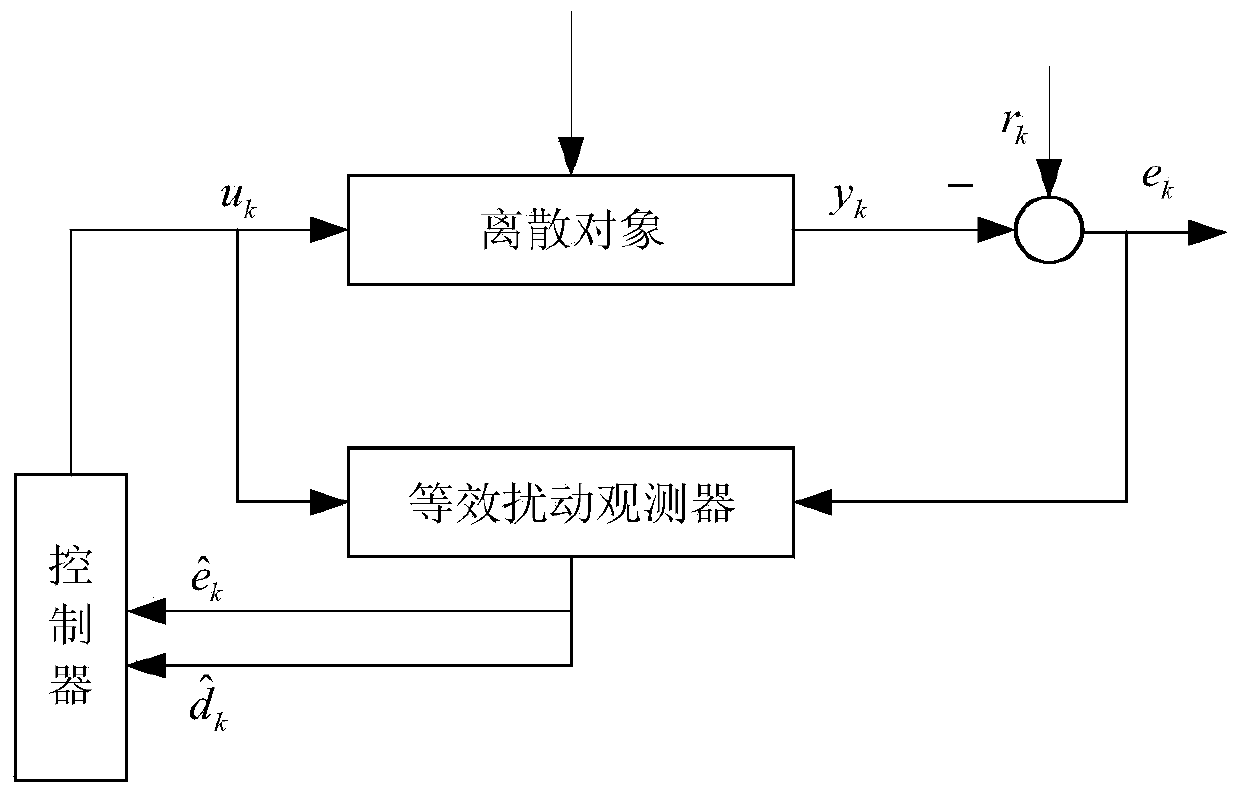
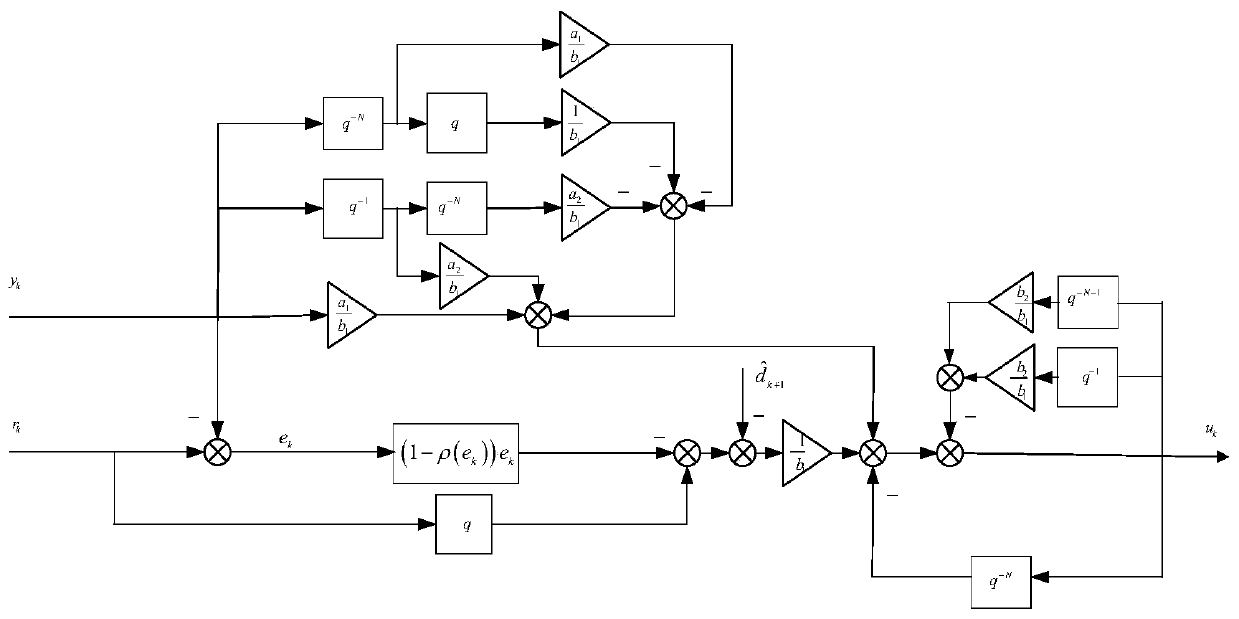
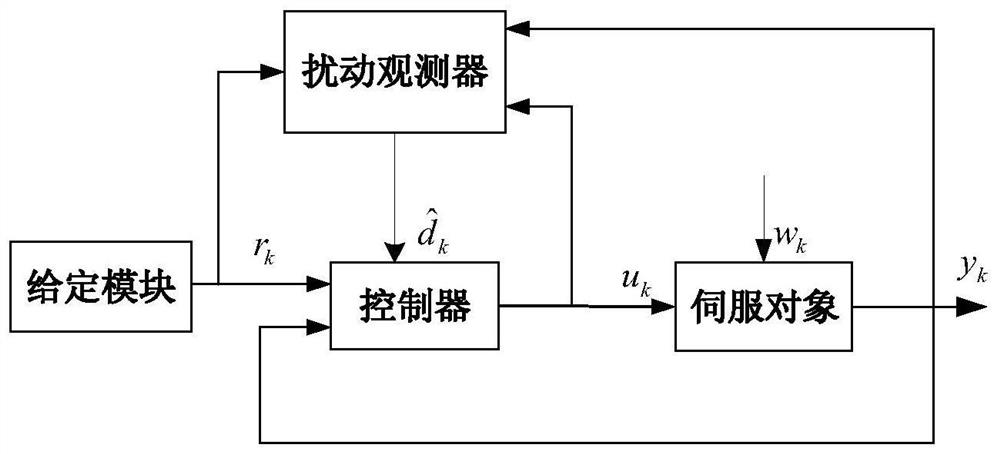
The invention discloses a servo system non-switching attraction repetitive control method adopting equivalent disturbance compensation. According to the method, a given module generates periodical reference signals, a periodical feedback link is created, equivalent disturbance compensation is introduced into a non-switching attraction law, and an observer is utilized to estimate equivalent disturbance; an ideal error dynamic state is established based on the non-switching attraction law, a controller is designed according to the ideal error dynamic state, and a signal obtained through calculation is used as control input of a servo system; and specific controller parameter setting can be performed according to system convergence performance representing indexes, and calculation formulas ofa monotone decreasing region, an absolute attraction layer, a steady-state error zone boundary and the maximum number of steps of a tracking error entering a steady-state error zone for the first time, all of which represent a tracking error convergence process, are given. According to the non-switching attraction repetitive controller with the equivalent disturbance compensation function, through estimation of equivalent disturbance, system tracking precision can be improved, and periodical disturbance can be completely suppressed.
Owner:ZHEJIANG UNIV OF TECH
Automatic deviation correction method and system for operation of underwater robot, medium and product
The invention discloses an automatic deviation correction method and system for operation of an underwater robot, a medium and a product, and relates to the field of general control or adjustment systems.The method comprises the steps that a weld seam image is obtained, filtering parameters are adjusted according to the noise intensity of a local image in the weld seam image, and a noise reduction image is obtained; performing double-layer threshold segmentation on the noise-reduced image to obtain a binary image; setting a plurality of detection areas in the binarized image, determining an effective detection area, converting edge feature points in the effective detection area into coordinate data, and performing partition weighted fitting to obtain an initial weld direction; constructing a dynamic error band, taking the coordinate points outside the dynamic error band as candidate abnormal points, determining a final abnormal point in the candidate abnormal points in combination with continuity criteria of adjacent feature points, and re-fitting the remaining coordinate points to obtain a target weld direction; and the target welding seam direction is compared with the reference direction, and a graded deviation correction control signal is generated according to the deviation degree. According to the invention, the correction accuracy can be improved.

Owner:NANJING HAIRUN ROBOT TECH CO LTD
Servo system quick attraction repetitive control method adopting equivalent disturbance compensation
ActiveCN110716430APeriodic Interference SuppressionImprove tracking accuracyAdaptive controlControl engineeringTracking error convergence
A servo system quick attraction repetitive control method adopting equivalent disturbance compensation is characterized in that a continuous time quick attraction law is given, a quick attraction lawconvergence time is calculated, the quick attraction law is discretized, generation of periodic reference signals by a module is given, a periodic feedback element is constructed, the equivalent disturbance compensation is introduced into the quick attraction law, and equivalent disturbance is estimated through an observer; ideal error dynamics are constructed based on the quick attraction law, acontroller is designed according to the ideal error dynamics, and signals obtained through calculation are used as control inputs of a servo system; and controller parameter setting is carried out according to indicators representing the system convergence performance, and calculation formulas for a monotonic decreasing region, an absolute attraction layer, a steady-state error band boundary and the maximum number of steps for the initial entry of tracking errors into a steady-state error band, which represent a tracking error convergence process, are given. The quick attraction repetitive controller with the equivalent disturbance compensation provided by the invention has the advantages that through equivalent disturbance estimation, the system tracking precision can be improved, and periodic disturbances can be completely inhibited.
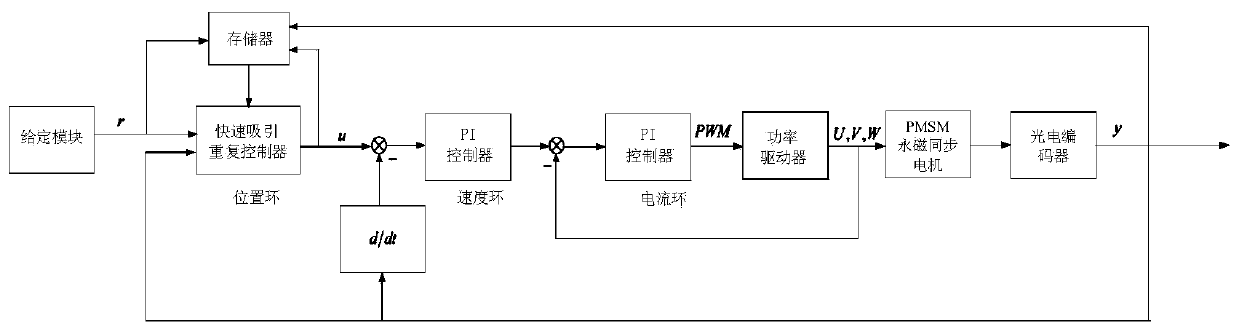
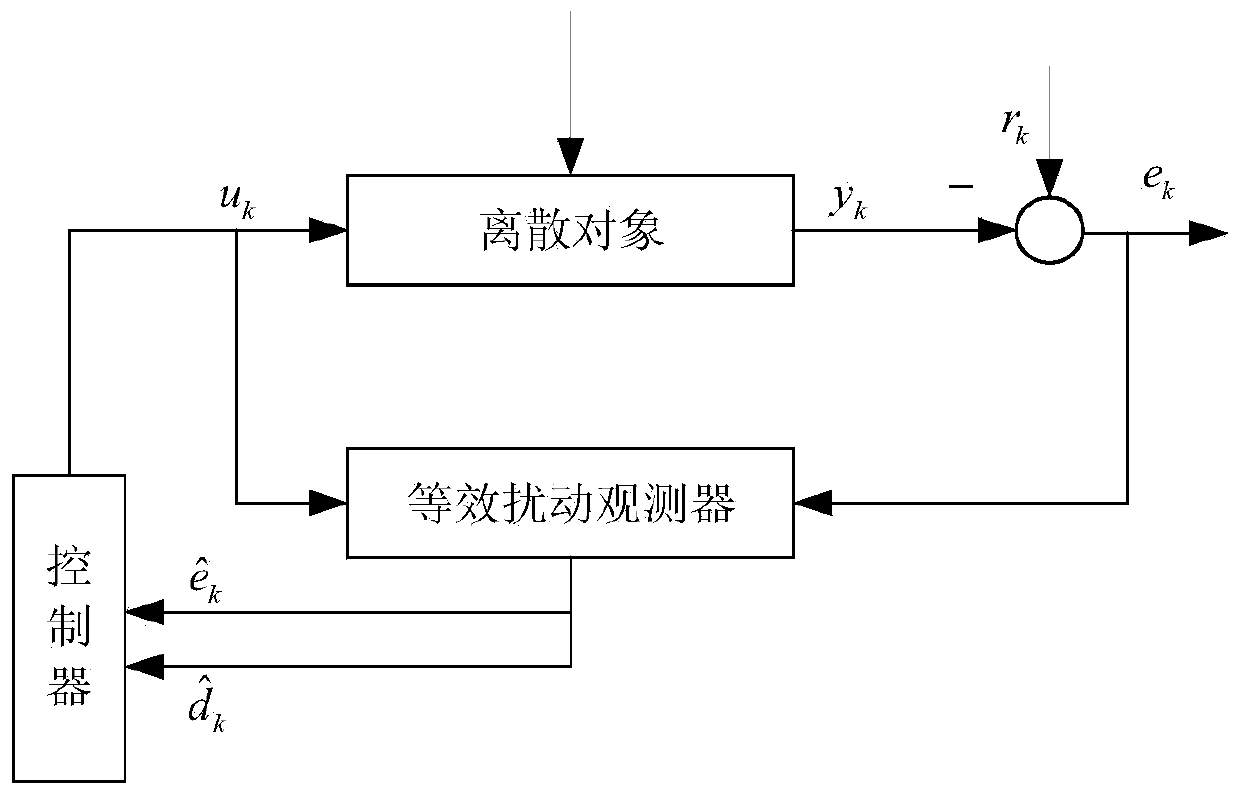
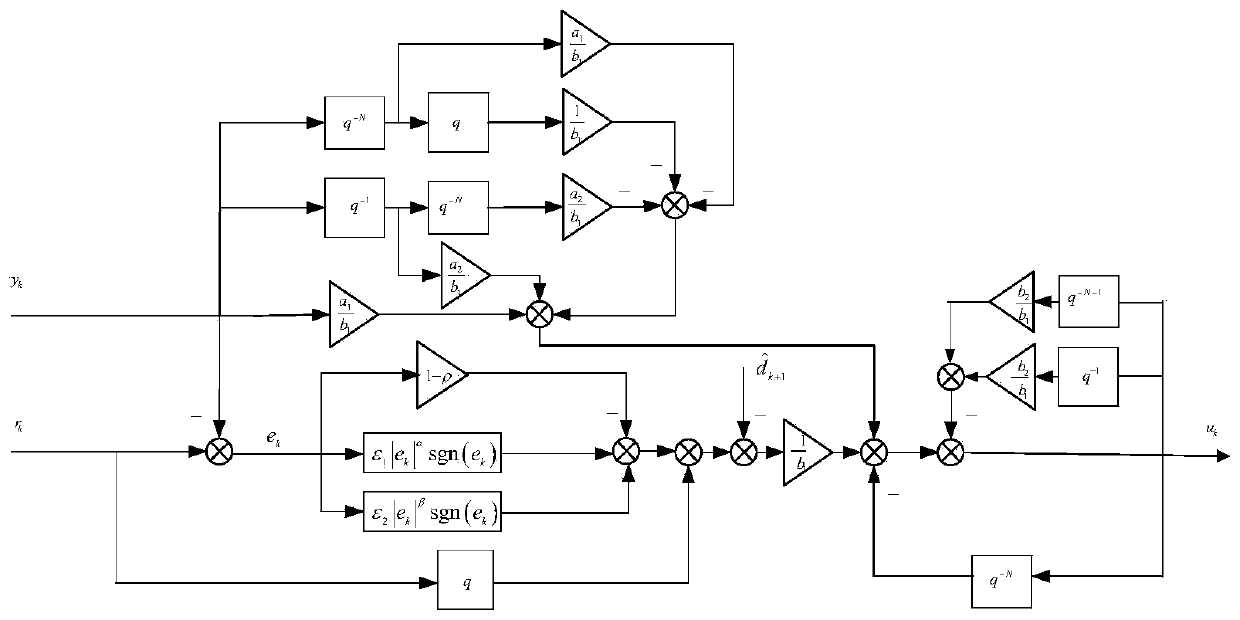
Owner:ZHEJIANG UNIV OF TECH
Power-off protection control method, system and device for embroidery frame of embroidery machine
ActiveCN114753072APrecise retrievalReduce manufacturing costAuxillary devicesControl engineeringElectric machinery
The invention relates to a power-off protection control method for an embroidery frame of an embroidery machine, and the method specifically comprises the steps: obtaining a relative coordinate of the embroidery frame at a power-off position, and obtaining a motor shaft position of the embroidery frame at the power-off position through a motor encoder; after the embroidery machine is powered on, when the embroidery frame is positioned to the power-off position again, the following steps S1-S2 are executed; s1, controlling the tabouret to move to a rough error band of the relative coordinates, wherein the rough error band is an error range of positioning the tabouret by a sensor; and S2, according to a signal of a motor encoder, a motor shaft of the tabouret is controlled to rotate to the position of the motor shaft, so that the tabouret further moves to an accurate error belt of the relative coordinates, and the accurate error belt is smaller than and is contained in the rough error belt. According to the method, the position during power failure can be accurately found after power failure, a high-precision positioning sensor is not needed, only an encoder is added to the motor, the manufacturing cost is low, the structure is simple, and maintenance is easy.
Owner:ZHEJIANG YUELONG SEWING EQUIP
Comprehensive noise reduction performance evaluation method for nonlinear ultrasonic detection signal noise reduction algorithm
The invention provides a comprehensive noise reduction performance evaluation method for a nonlinear ultrasonic detection signal noise reduction algorithm, and the method comprises the steps: firstly constructing a multi-working-condition noise reduction performance pre-screening mechanism based on error band analysis based on early-stage experimental data, and then introducing a radar map as an evaluation tool for the comprehensive noise reduction effect of the signal noise reduction algorithm. The noise reduction effects of a moving average method (MA), a spectral subtraction method (SS), a short-time Fourier transform method (STFT), a wavelet transform method (WT) and an orthogonal matching pursuit algorithm (OMP) are compared, and finally a signal noise reduction algorithm with the optimal comprehensive efficiency is screened out. On the basis of algorithm optimization, quantitative mapping rules between microcrack three-dimensional geometric parameters and relative nonlinear coefficients are analyzed through regression modeling, and the significant level of the correlation degree of the relative nonlinear coefficients and microcrack size parameters is effectively improved; and a high-confidence theoretical support is provided for quantitative nondestructive detection of the microcracks in engineering practice.

Owner:BEIJING INST OF TECH
Method for evaluating insufficient power supply capacity of power system by considering uncertainty of new energy
PendingCN120545960AGeneration forecast in ac networkSingle network parallel feeding arrangementsLoad SheddingElectricity system
The invention provides an electric power system power supply capacity insufficiency evaluation method considering new energy uncertainty, and the method comprises the steps: building the probability distribution of electric quantity prediction results at different time scales in a to-be-evaluated time period through Gaussian mixture distribution, and obtaining the probability distribution of the electric quantity prediction results in a total time period; constructing a joint probability density function according to the prediction error distribution of the generated power of the plurality of wind power plants and the prediction error distribution of the generated power of the plurality of photovoltaic power stations, and obtaining a space joint probability density function; establishing the probability density distribution of a wind-solar joint prediction error band in the to-be-evaluated time period according to the probability distribution of the electric quantity prediction result in the total time period and the spatial joint probability density function; calculating to obtain load shedding probability distribution through probability density distribution of a day-ahead operation domain and a wind-solar combined prediction error band; therefore, the risk of insufficient power supply is determined. And flexible assessment of the short-term scale power supply capacity insufficiency risk in the power system with short-term uncertainty in the new energy is realized.

Owner:TSINGHUA UNIVERSITY
Uncertainty Estimation Method of Wind Speed Fluctuation Based on Instantaneous Model of Effective Turbulence Intensity
ActiveCN103678940BHigh precisionAvoid Redundant Spinning Hot StandbySpecial data processing applicationsPeaking power plantWavelet decomposition
The invention relates to a method for estimating wind speed fluctuation uncertainty based on an effective turbulence intensity instantaneous model, and solves the problems that error bands in the same width are given in an area with low wind speed and an area with high wind speed and an overlarge prediction error exists, does not accord with actual conditions and is not favorable for making a reasonable scheduling plane for a power grid in a method for estimating the uncertainty of wind speed fluctuation based on the current theoretical model. Instantaneous standard deviation of turbulence residual difference is obtained through a Mallat wavelet decomposition and reconstruction algorithm, and the uncertainty of the wind speed fluctuation is estimated by fitting through the effective turbulence intensity instantaneous model according to average wind speed. The method is used for predicting the power of a wind power plant, so that the reasonable scheduling plant is made for the power grid, spinning reserve is determined, and the operation of the power grid is safely and economically guaranteed.


Owner:HARBIN INST OF TECH
Finite value power attraction repetitive controller design method
PendingCN112068423AFast convergenceEffective Interference SuppressionAdaptive controlControl engineeringTracking error convergence
A finite value power attraction repetitive controller design method comprises the steps that a given module generates periodic reference signals, and a periodic feedback link is constructed; equivalent disturbance compensation is introduced into a finite value power attraction law, and equivalent disturbance is estimated through a disturbance observer; an ideal error dynamic state (an attraction law with an interference suppression effect) is constructed, a controller is designed according to the ideal error dynamic state, and a signal obtained by current calculation is served as input of a servo system; and specific controller parameter setting is carried out according to indexes representing system convergence performance, and a computational formula representing an attraction domain boundary, a monotone decreasing area, an absolute attraction layer, a steady-state error band and the maximum convergence step number in a tracking error convergence process is given. The finite value power attraction repetitive controller provided by the invention can completely inhibit periodic components of an interference signal and inhibit the influence of aperiodic components.


Owner:ZHEJIANG UNIV OF TECH
1/2 power finite value attraction repetitive control method for servo motor driving system
ActiveCN111835250AFast convergenceEffective Interference SuppressionElectronic commutation motor controlAC motor controlControl engineeringTracking error convergence
The invention discloses a 1 / 2 power finite value attraction repetitive control method for a servo motor driving system. The method comprises the steps of enabling a given module to generate a periodicreference signal, and constructing a periodic feedback link; introducing equivalent disturbance compensation into a 1 / 2 power finite value attraction law, and estimating equivalent disturbance through a disturbance observer; constructing an ideal error dynamic state (an attraction law with an interference suppression effect), designing a controller according to the ideal error dynamic state, andtaking a signal obtained by current calculation as the input of a servo system; carrying out specific controller parameter setting according to indexes representing system convergence performance, andproviding a computational formula representing an attraction domain, a monotone decreasing area, an absolute attraction layer, a steady-state error band and the maximum convergence step number in thetracking error convergence process. According to the 1 / 2 power finite value attraction repetitive controller provided by the invention, complete suppression of periodic components of interference signals can be realized, and the influence of aperiodic components of the interference signals is suppressed.


Owner:ZHEJIANG UNIV OF TECH
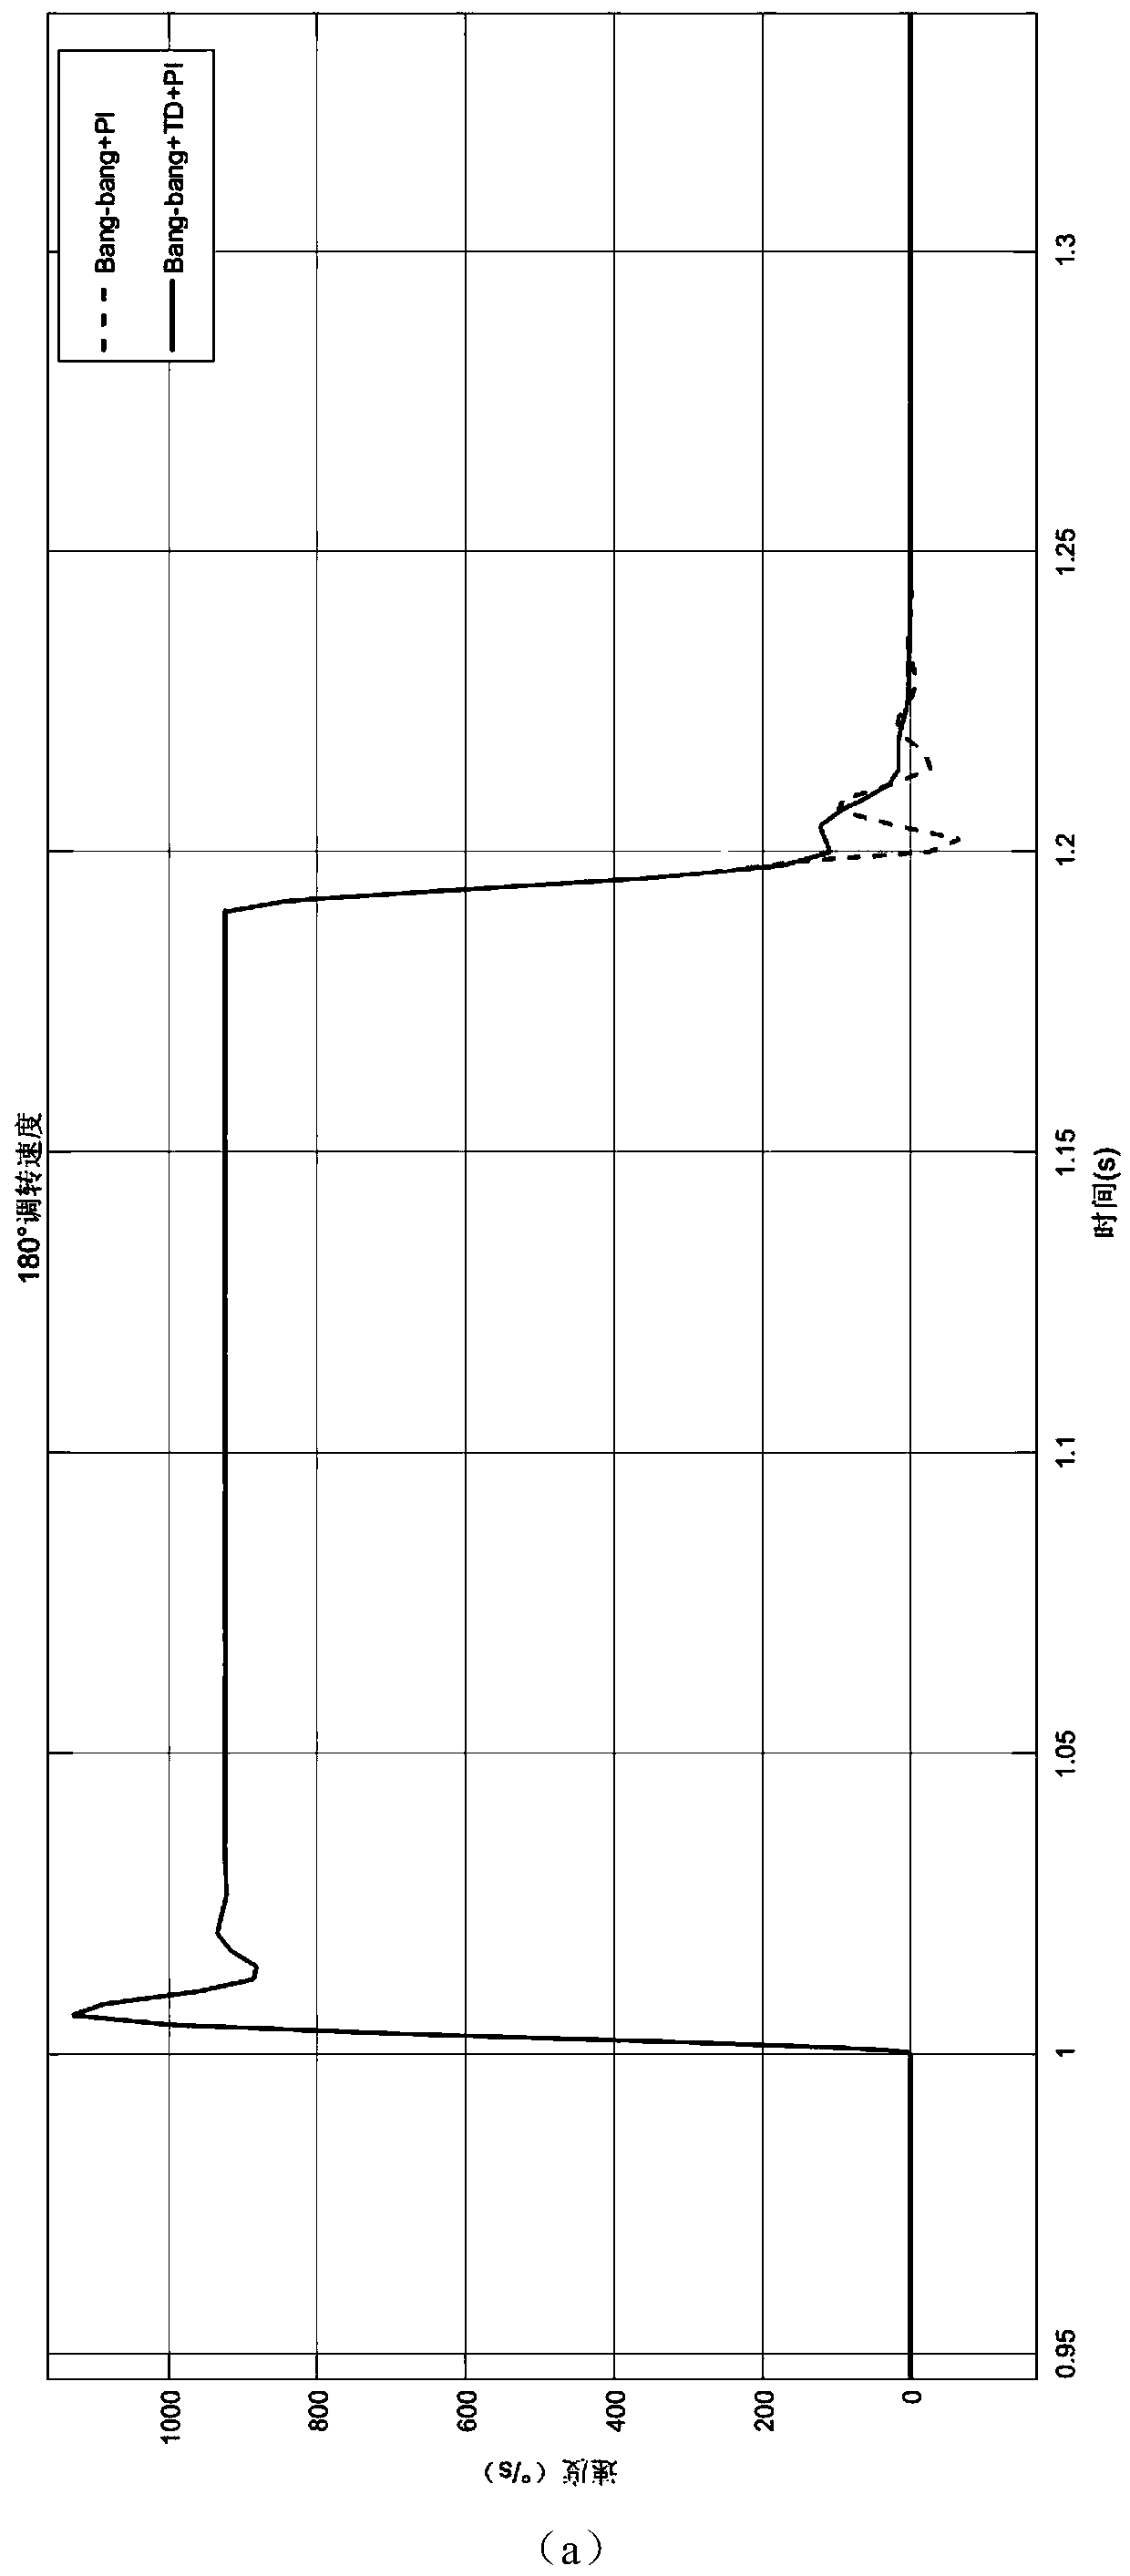
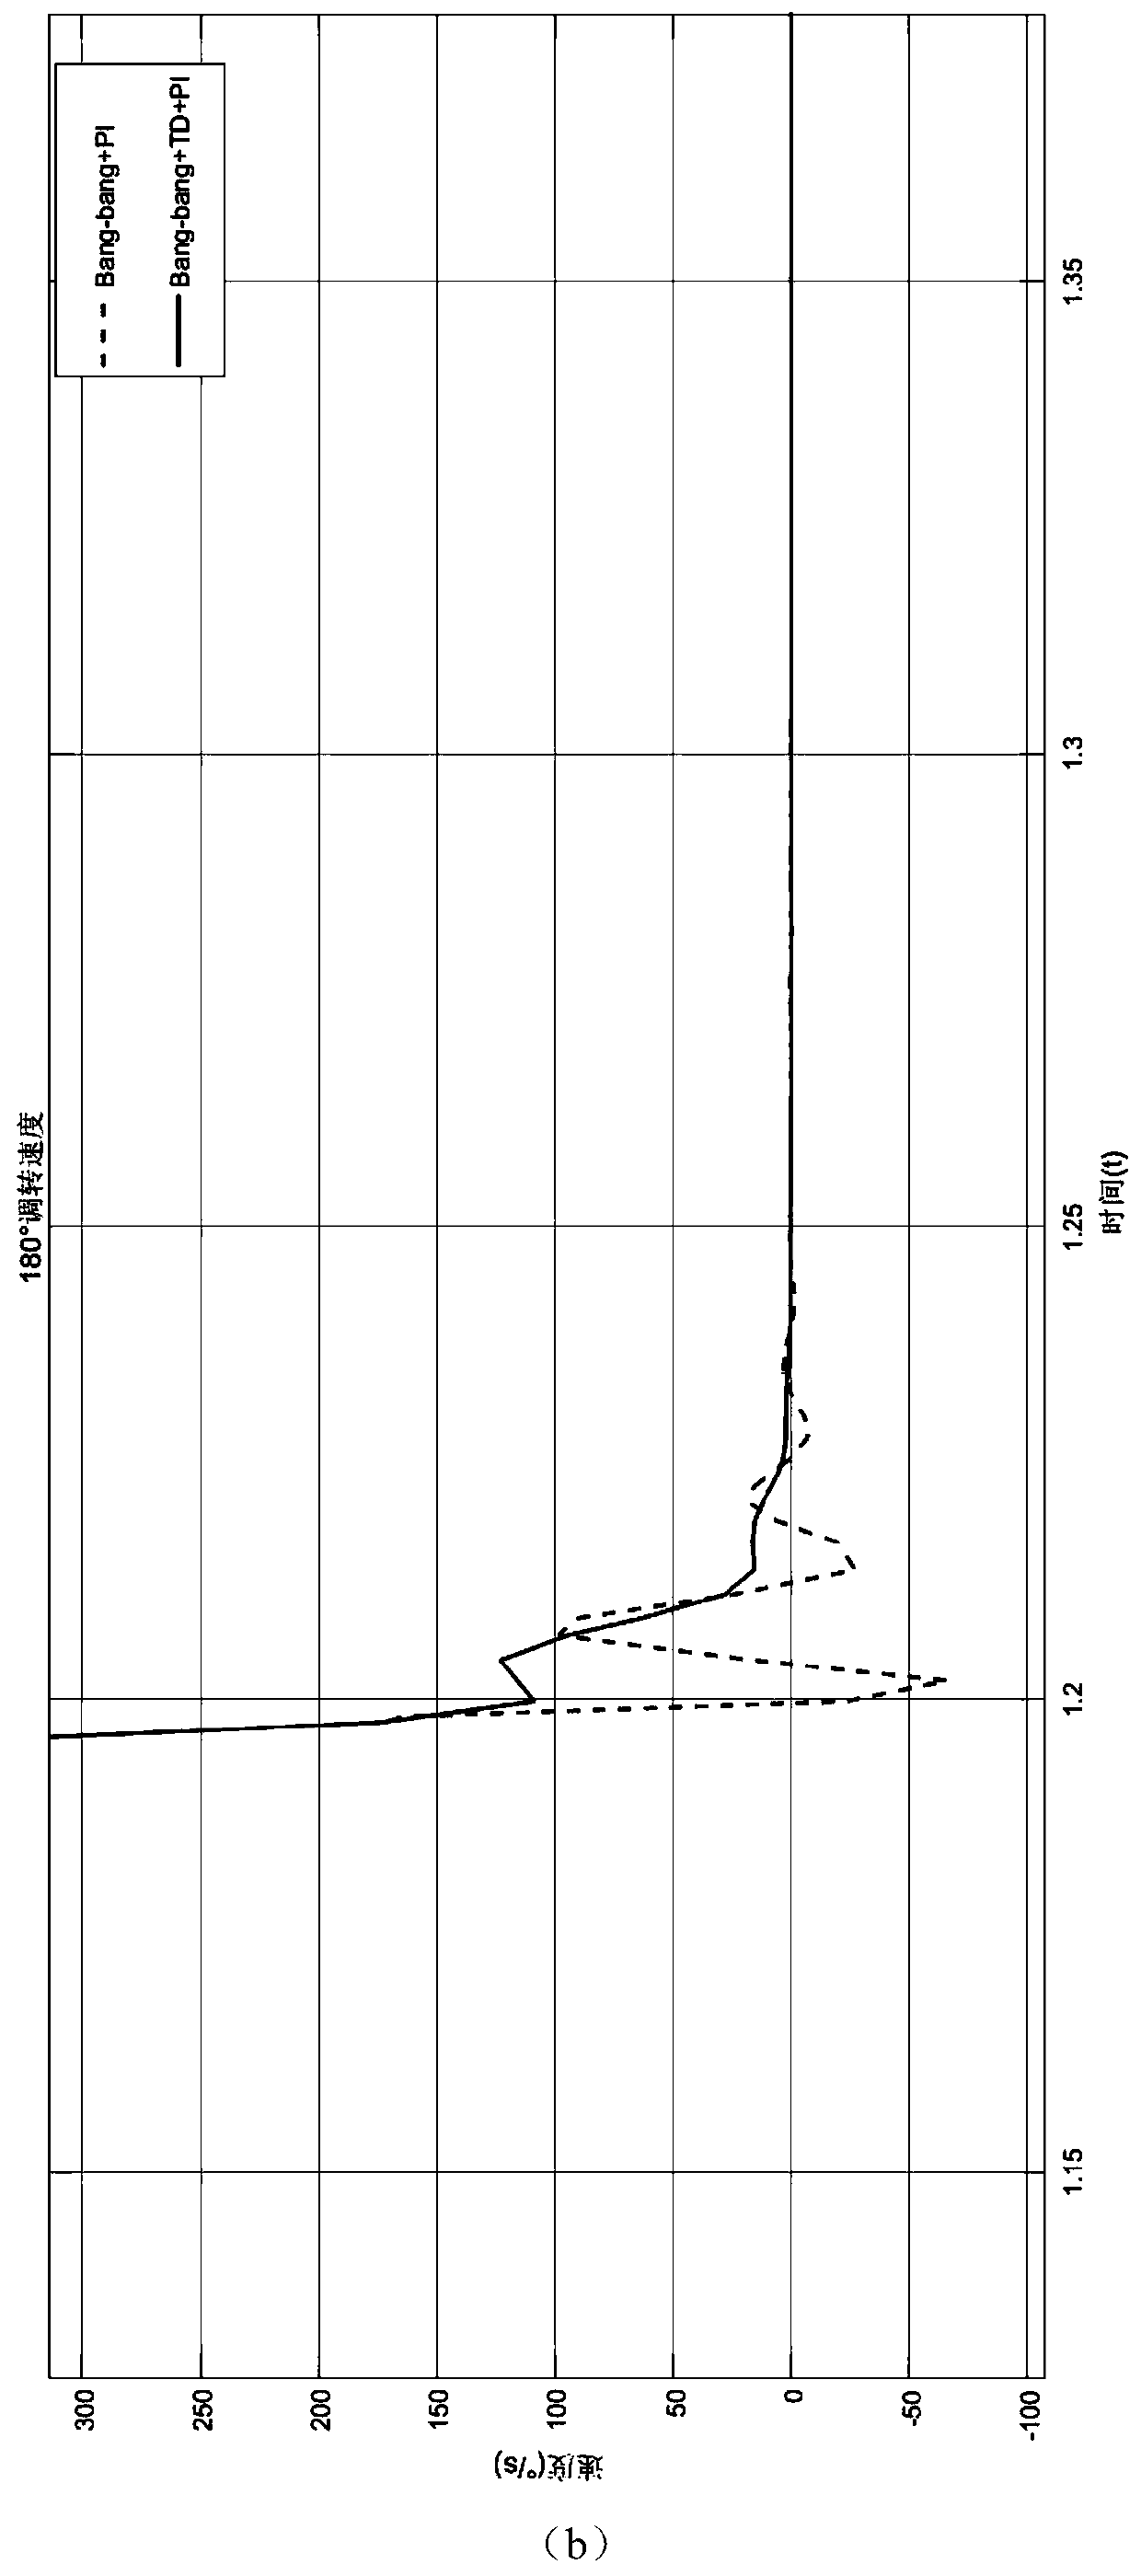
Quick turning method for photoelectric equipment by combining bang-bang control and overshoot-free predictive control
ActiveCN111427386AImprove speedImprove stabilityOptical detectionControl using feedbackTarget captureControl engineering
The invention discloses a quick turning method for photoelectric equipment by combining bang-bang control and overshoot-free predictive control. According to the method, the advantage that bang-bang control is high in large-range turning speed is combined, and no-overshoot prediction control is used in the turning process, so that the turning time of the system is shortened, and the target capturing state and the tracking state can be stably switched. The system receives a guide signal and controls a driving motor to turn with the maximum driving force through bang-bang, and when approaching the target, the system is switched to non-overshoot prediction control to quickly approach the target and meet a target capture condition. According to the method, the system is optimized from the minimum time control problem; the advantage that the bang-bang control is high in turning speed in a large range is brought into full play; the characteristics that the system can quickly enter a steady state within limited time without overshoot prediction control energy are utilized, so that oscillation is not generated when the position of the system enters an error band; the advantages of the twocontrol methods are complementary; and the whole-process turning speed and stability of the photoelectric equipment are improved under the condition that the cost is not increased.
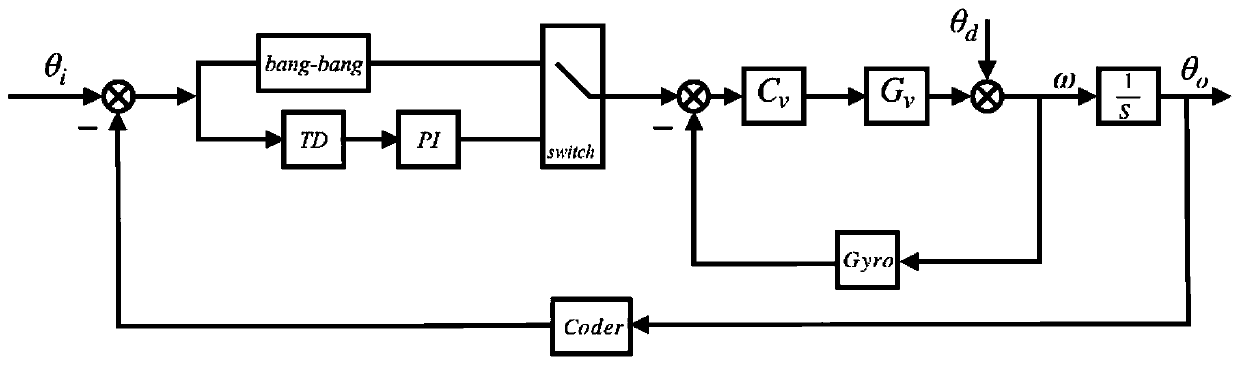
Owner:INST OF OPTICS & ELECTRONICS - CHINESE ACAD OF SCI
Design method of digital repetitive controller for attraction of servo motor at specified time
ActiveCN111752149AEffective Interference SuppressionHigh control precisionAdaptive controlControl engineeringDesign control
The invention relates to a design method of a digital repetitive controller for attraction of a servo motor at a specified time. The design method comprises the following steps that: a given module generates a periodic reference signal and constructs a periodic feedback link; equivalent disturbance compensation is introduced into a specified time attraction law, and equivalent disturbance is estimated by using a disturbance observer; an ideal error dynamic state (an attraction law with an interference suppression effect) is constructed, a controller is designed according to the ideal error dynamic state, and a signal obtained by current calculation is taken as the input of a servo system; specific controller parameter setting is carried out according to indexes representing system convergence performance, and a computational formula representing an attraction domain, a monotone decreasing area, an absolute attraction layer, a steady-state error band and the maximum convergence step number in the tracking error convergence process is given. The specified time attraction repetitive controller provided by the invention can completely inhibit periodic components of interference signals and inhibit the influence of aperiodic components of the interference signals.


Owner:ZHEJIANG UNIV OF TECH
Comprehensive evaluation system for multi-dimensional operation indexes of wind power plant
InactiveCN121503088AGeometric CADDesign optimisation/simulationStatistical ConfidenceAtmospheric sciences
The invention relates to the technical field of data analysis, in particular to a wind power plant multi-dimensional operation index comprehensive evaluation system which comprises a deviation benchmark construction module, a gradient environment mapping module, a torque ripple calculation module, a dynamic interval construction module and an index generation module. In the method, a dynamic power confidence interval changing along with the environment in real time is generated by constructing a gradient vector containing a vertical height layer air density difference, finely simulating a torque pulsation waveform generated by environmental heterogeneity in a blade rotation period, quantifying a theoretical power fluctuation amplitude caused by the torque pulsation waveform, and superposing the theoretical power fluctuation amplitude to a reference error band; according to the method, a running state judgment boundary with more physical interpretation is established, meanwhile, a sensitivity weight is introduced by combining statistical morphological characteristics of wind energy flow distribution, a physical yaw angle is corrected and weighted, and multi-dimensional coupling evaluation of wind energy capturing efficiency and control precision of a unit on the basis of eliminating reasonable environmental disturbance is achieved.

Owner:华能吐鲁番风力发电有限公司
Equivalent Disturbance Compensation Method for Power Attraction Repeated Control of Periodic Servo System
ActiveCN110134014BEquivalent Disturbance CompensationFast convergenceAdaptive controlControl engineeringComputer science
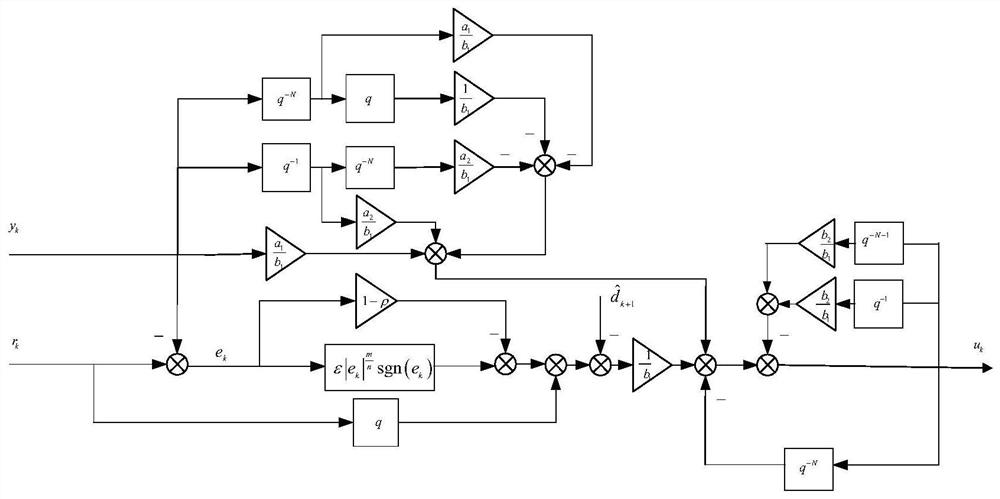
Owner:ZHEJIANG UNIV OF TECH
Full-range error on-line calibration device and calibration method for low-voltage current transformer
The application discloses a full-range error live calibration device and method for a low-voltage current transformer, comprising: a current control unit for outputting full-range calibration current control signals of each frequency; a hetero-frequency calibration current source for outputting full-range hetero-frequency current signals based on the current control signals and injecting the signals into the measured current transformer and a standard current transformer; an open current sensor for measuring a background current signal in real time; a signal decoupling unit for acquiring a mixed-frequency error voltage signal, eliminating a voltage component generated by the background current signal in the mixed-frequency error voltage signal, and acquiring a hetero-frequency error voltage signal; an error measurement unit for calculating ratio error and phase error of the measured current transformer based on the hetero-frequency standard signal and the hetero-frequency error voltage signal; and a data processing unit for determining calibration error under a power frequency frequency mapping based on the ratio error and the phase error under each hetero-frequency frequency.

Owner:CHINA ELECTRIC POWER RESEARCH INSTITUTE CO LTD +2
Gas transverse uniform output device
ActiveCN101413663BConsistent direction of flowUniform pressureGaseous fuel burnerEngineeringMechanical engineering
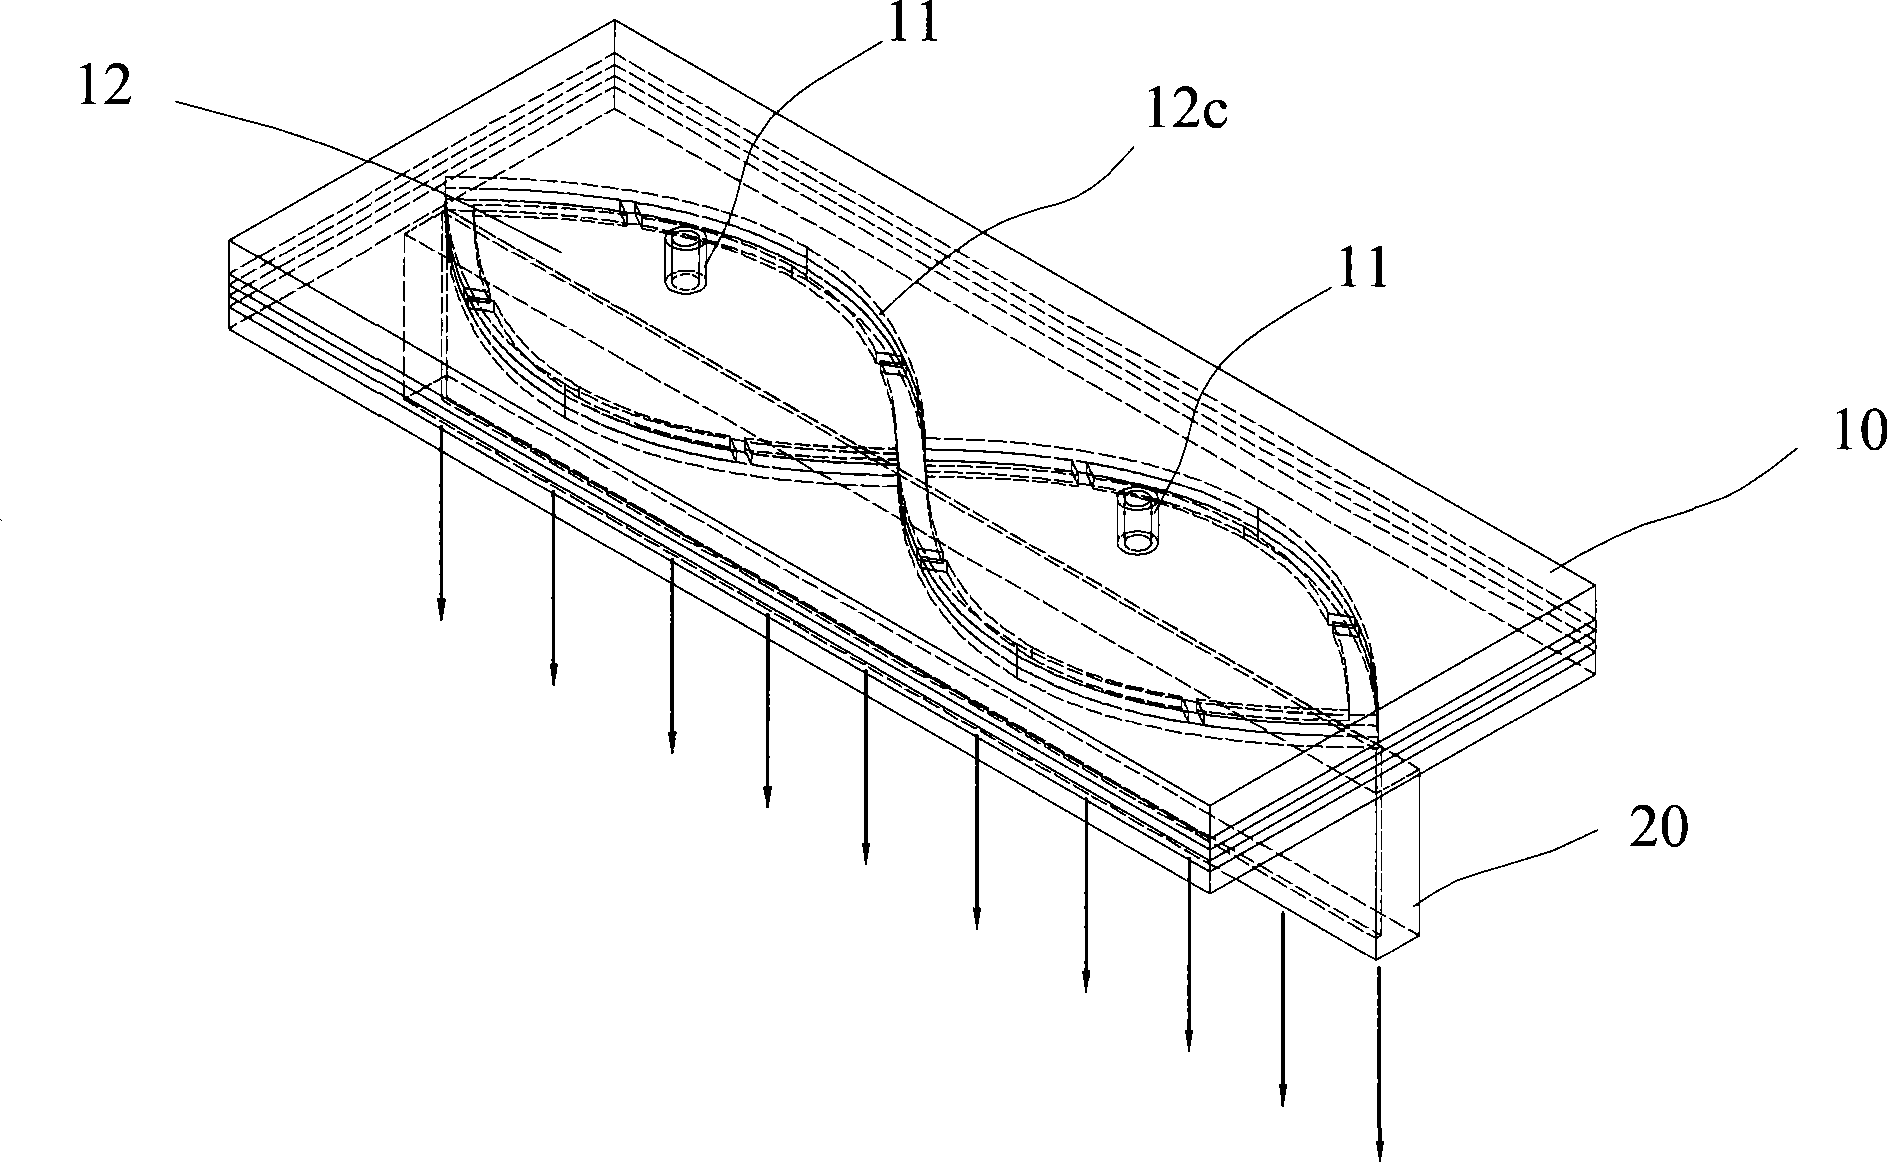
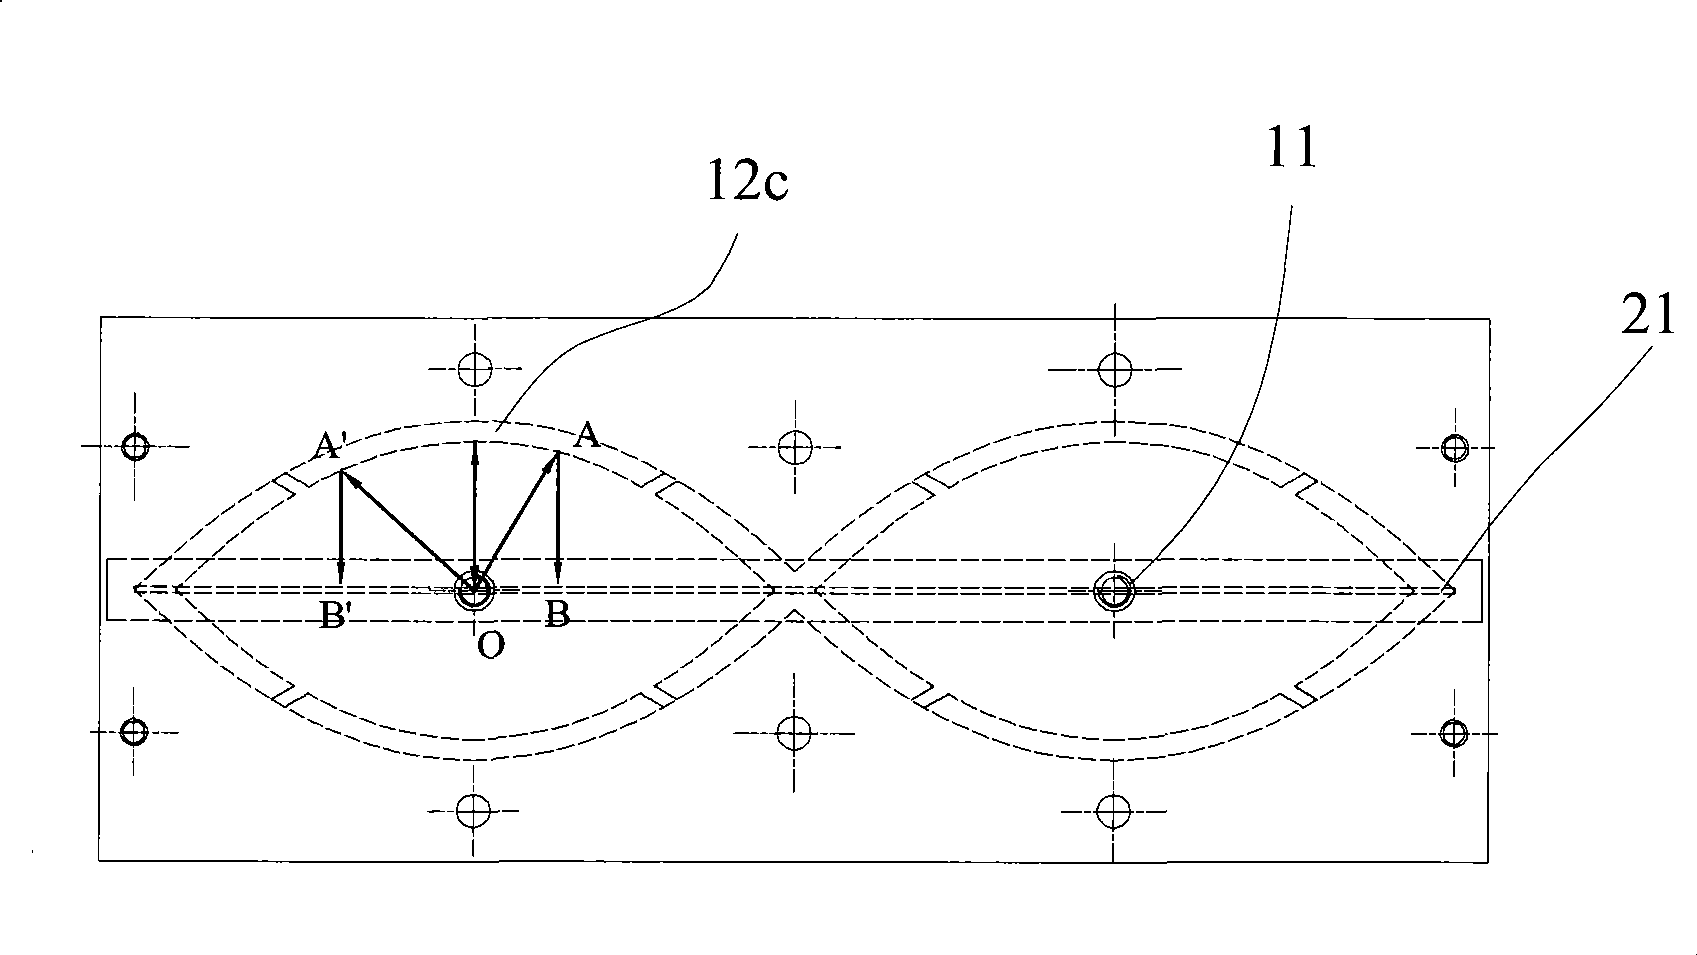
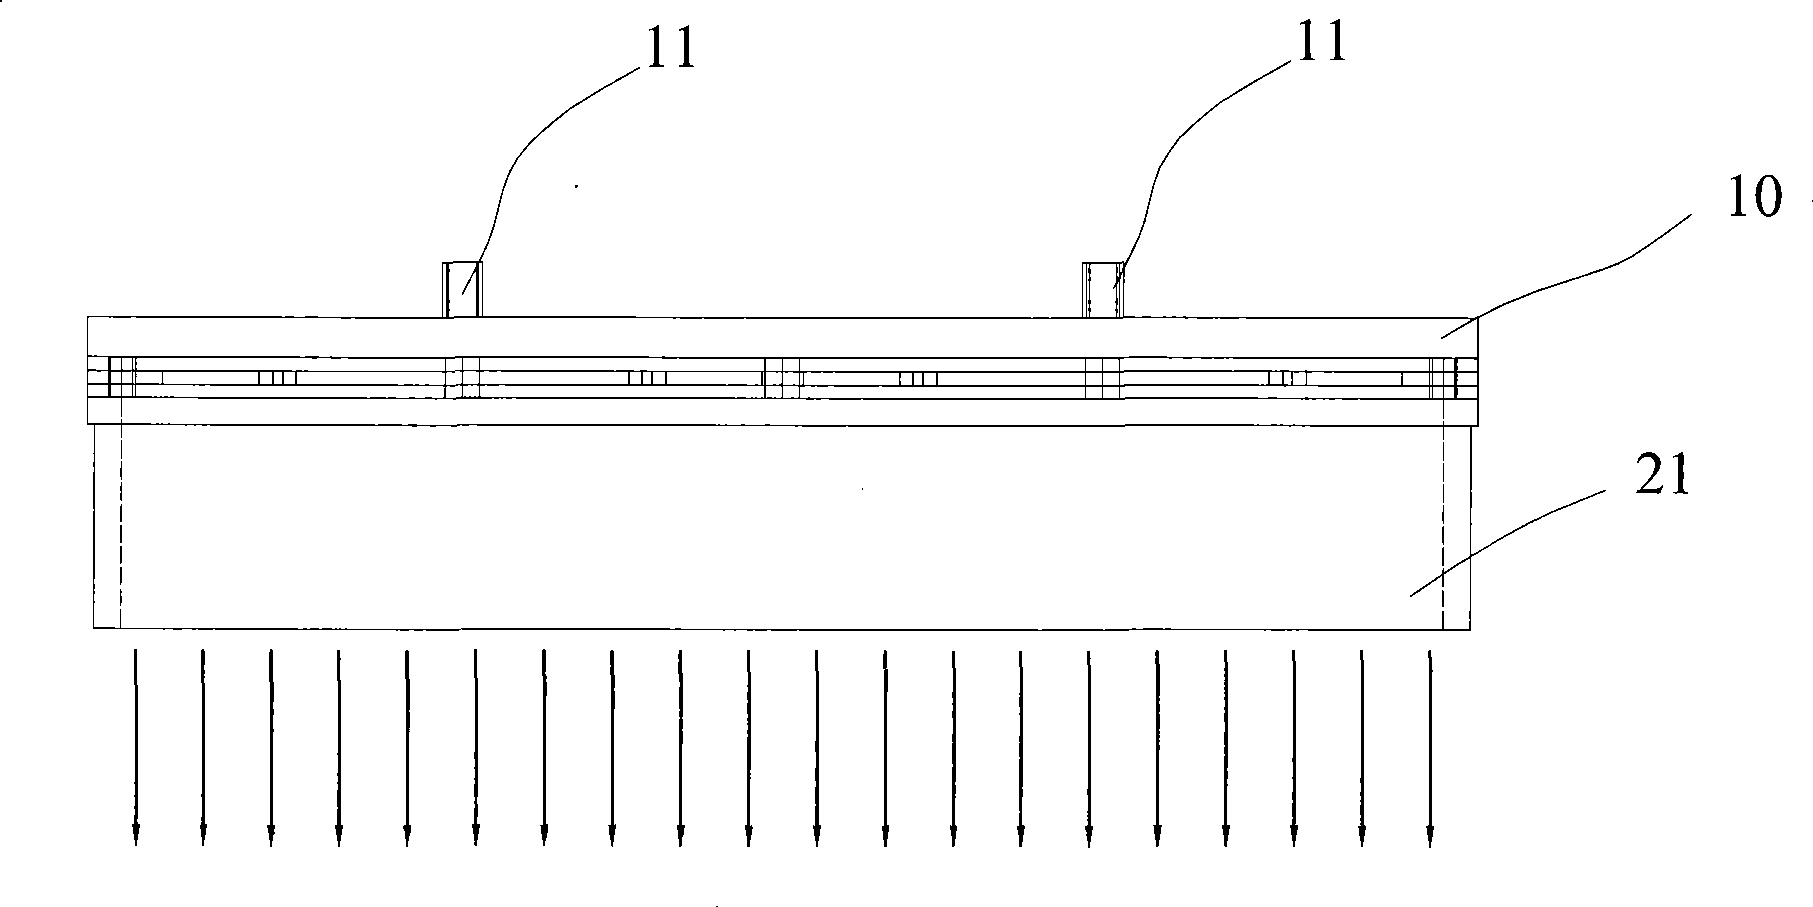
The invention relates to a device used for transversely and evenly outputting gas, which comprises a distribution part and a spout part, wherein, the distribution part includes at least one air inlet that is communicated with a flow passage formed inside the distribution part; the spout part is arranged at the bottom side of the distribution part and is internally provided with a narrow slit which has the fixed size and is communicated with the flow passage; furthermore, the gas flow paths around the position from the air inlet through the flow passage to the narrow slit are fixed value. By adopting the structure of the invention, the paths of the gas from the air inlet to the narrow slit are consistent in terms of theory, or the path distance difference is controlled within the error band according to the needs, so that the gas sprayed out from the spout part keeps uniform pressure along the length direction. In addition, the device has the advantages of simple structure, convenient processing and lower manufacturing cost.
Owner:上海誉辉化工有限公司
Buck type converter digital controller design method adopting interference filtering compensation
PendingCN114759788ASuppress interferenceImprove tracking accuracyDc-dc conversionElectric variable regulationController designError band
The invention discloses a design method of a Buck type converter digital controller adopting interference filtering compensation. An interference compensator based on a moving average filtering technology is adopted and is embedded into a constraint variable speed attraction law, and an ideal error dynamic state with interference suppression capability is constructed; and dynamically designing a digital controller according to the ideal error, and taking a control signal obtained by calculation as a control input signal of the Buck-type converter. Specific controller parameter setting work can be carried out according to indexes of a system attraction process, and expressions representing an absolute attraction layer and a steady-state error band boundary of the system attraction process are given. According to the digital controller design method provided by the invention, various interference signals such as system flutter and nonlinearity can be effectively suppressed, output voltage ripples can be effectively reduced, and inductive current constraint hardware protection is realized.


Owner:TAIZHOU UNIV
A q-learning-based trajectory planning method for concrete placing robot
ActiveCN113062601BRelatively small errorIncrease autonomyProgramme-controlled manipulatorBuilding material handlingTrajectory planningControl theory
The invention relates to a novel trajectory planning scheme of an intelligent concrete placing robot, which is suitable for autonomous pouring control of a concrete placing robot, avoids complex kinematic inverse solution interpolation calculation, and belongs to the field of intelligent manufacturing. The invention designs a general trajectory planning framework, including the rapid movement process of the placing robot from the initial state to the starting point of the path, and the reset from the ending point of the path to the initial state; . In the process of fast motion, a simple interior point method is used to optimize the inverse solution aiming at time optimization, and a cubic polynomial is used to fit the trajectory. In the process of continuous concrete pouring, the path to be poured at the end of the placing robot is formed into an error band of a certain area. The Q-learning algorithm is used to divide the formed path error band into regions, and the divided regions are divided according to the pouring goals and constraints. Given the reward value, the Q-value training is performed on the given grid, and finally the action sequence of each joint of the robot is formed, and the robot action is directly obtained, which avoids the complex trajectory planning process based on kinematic inverse solution optimization.
Owner:TONGJI UNIV
A Repeated Control Method of Inverter Based on Law of Attraction
The invention discloses an inverter repetition control method based on the law of attraction. The equivalent interference second-order difference compensation term is embedded into the arctangent attraction law; according to the arctangent attraction law, the e / v signal conversion module is constructed, and its output signal is used for the correction amount of the repetitive controller; then the output signal of the repetitive controller is calculated As an input to the inverter object, make the inverter system follow the reference signal changes. The specific controller parameter tuning can be carried out according to the absolute attraction layer, the steady-state error band and the index of the maximum number of steps required for the tracking error to enter the steady-state error band for the first time. The invention provides a discrete repetitive controller based on arctangent attraction law designed in time domain, with good control precision, completely suppressing interference signals of homogeneous harmonics and even harmonics, and effectively suppressing fractional harmonics.


Owner:TAIZHOU UNIV