
Patents
Literature
63 results about "Lyapunov equation" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
In control theory, the discrete Lyapunov equation is of the form AXAᴴ-X+Q=0 where Q is a Hermitian matrix and Aᴴ is the conjugate transpose of A. The continuous Lyapunov equation is of form: AX+XAᴴ+Q=0. The Lyapunov equation occurs in many branches of control theory, such as stability analysis and optimal control. This and related equations are named after the Russian mathematician Aleksandr Lyapunov.
Remote operating robot fixed time control method based on rapid terminal sliding mode
ActiveCN105319972AFast convergenceImprove anti-interference abilityAdaptive controlRobotic systemsSynchronous control
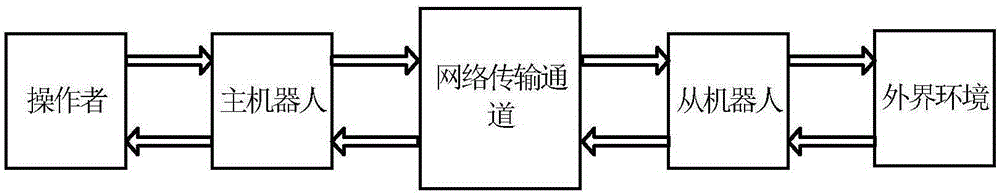
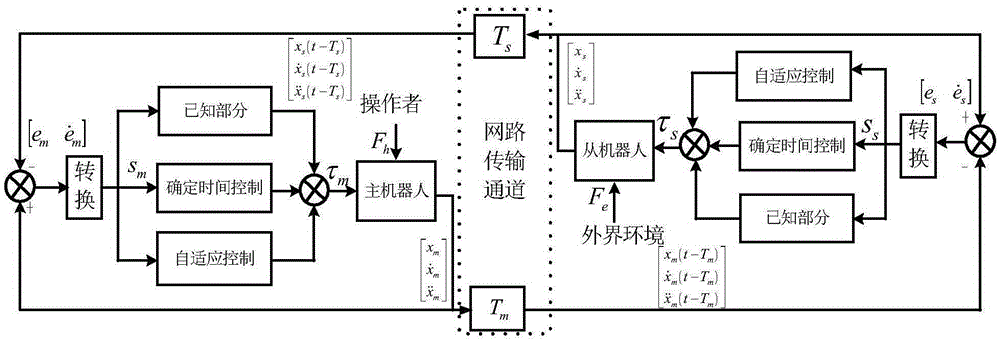
The invention relates to the technical field of remote operating robot synchronous control, specifically discloses a remote operating robot fixed time control method based on a rapid terminal sliding mode. The method includes: selecting a master robot and a slave robot to form a remote operating system, measuring system parameters of the master robot and the slave robot respectively, measuring position information of the master robot and the slave robot on line, obtaining speed information of the master robot and the slave robot, designing a rapid terminal sliding mode surface, based on the designed rapid terminal sliding mode surface, using the system parameters of the main robot and the slave robot to design a self-adaptive fixed time controller, and using a Lyapunov equation to provide a relational expression between a parameter self-adaptive law, controller parameters, sliding mode surface parameters and system convergence time, thereby determining the controller parameters and the sliding mode surface parameters according to requirements of practical application for system convergence time and a relational expression between the system parameters and the system convergence time. The remote operating robot fixed time control method based on the rapid terminal sliding mode makes up for the defects in control speed and control accuracy of an existing remote operating robot system control method.
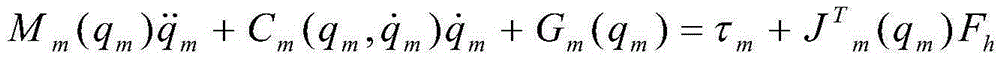
Owner:YANSHAN UNIV
Optimal sensor and actuator deployment for system design and control
InactiveUS20150095000A1Easy to placeGeometric CADComputation using non-denominational number representationSystems designEngineering
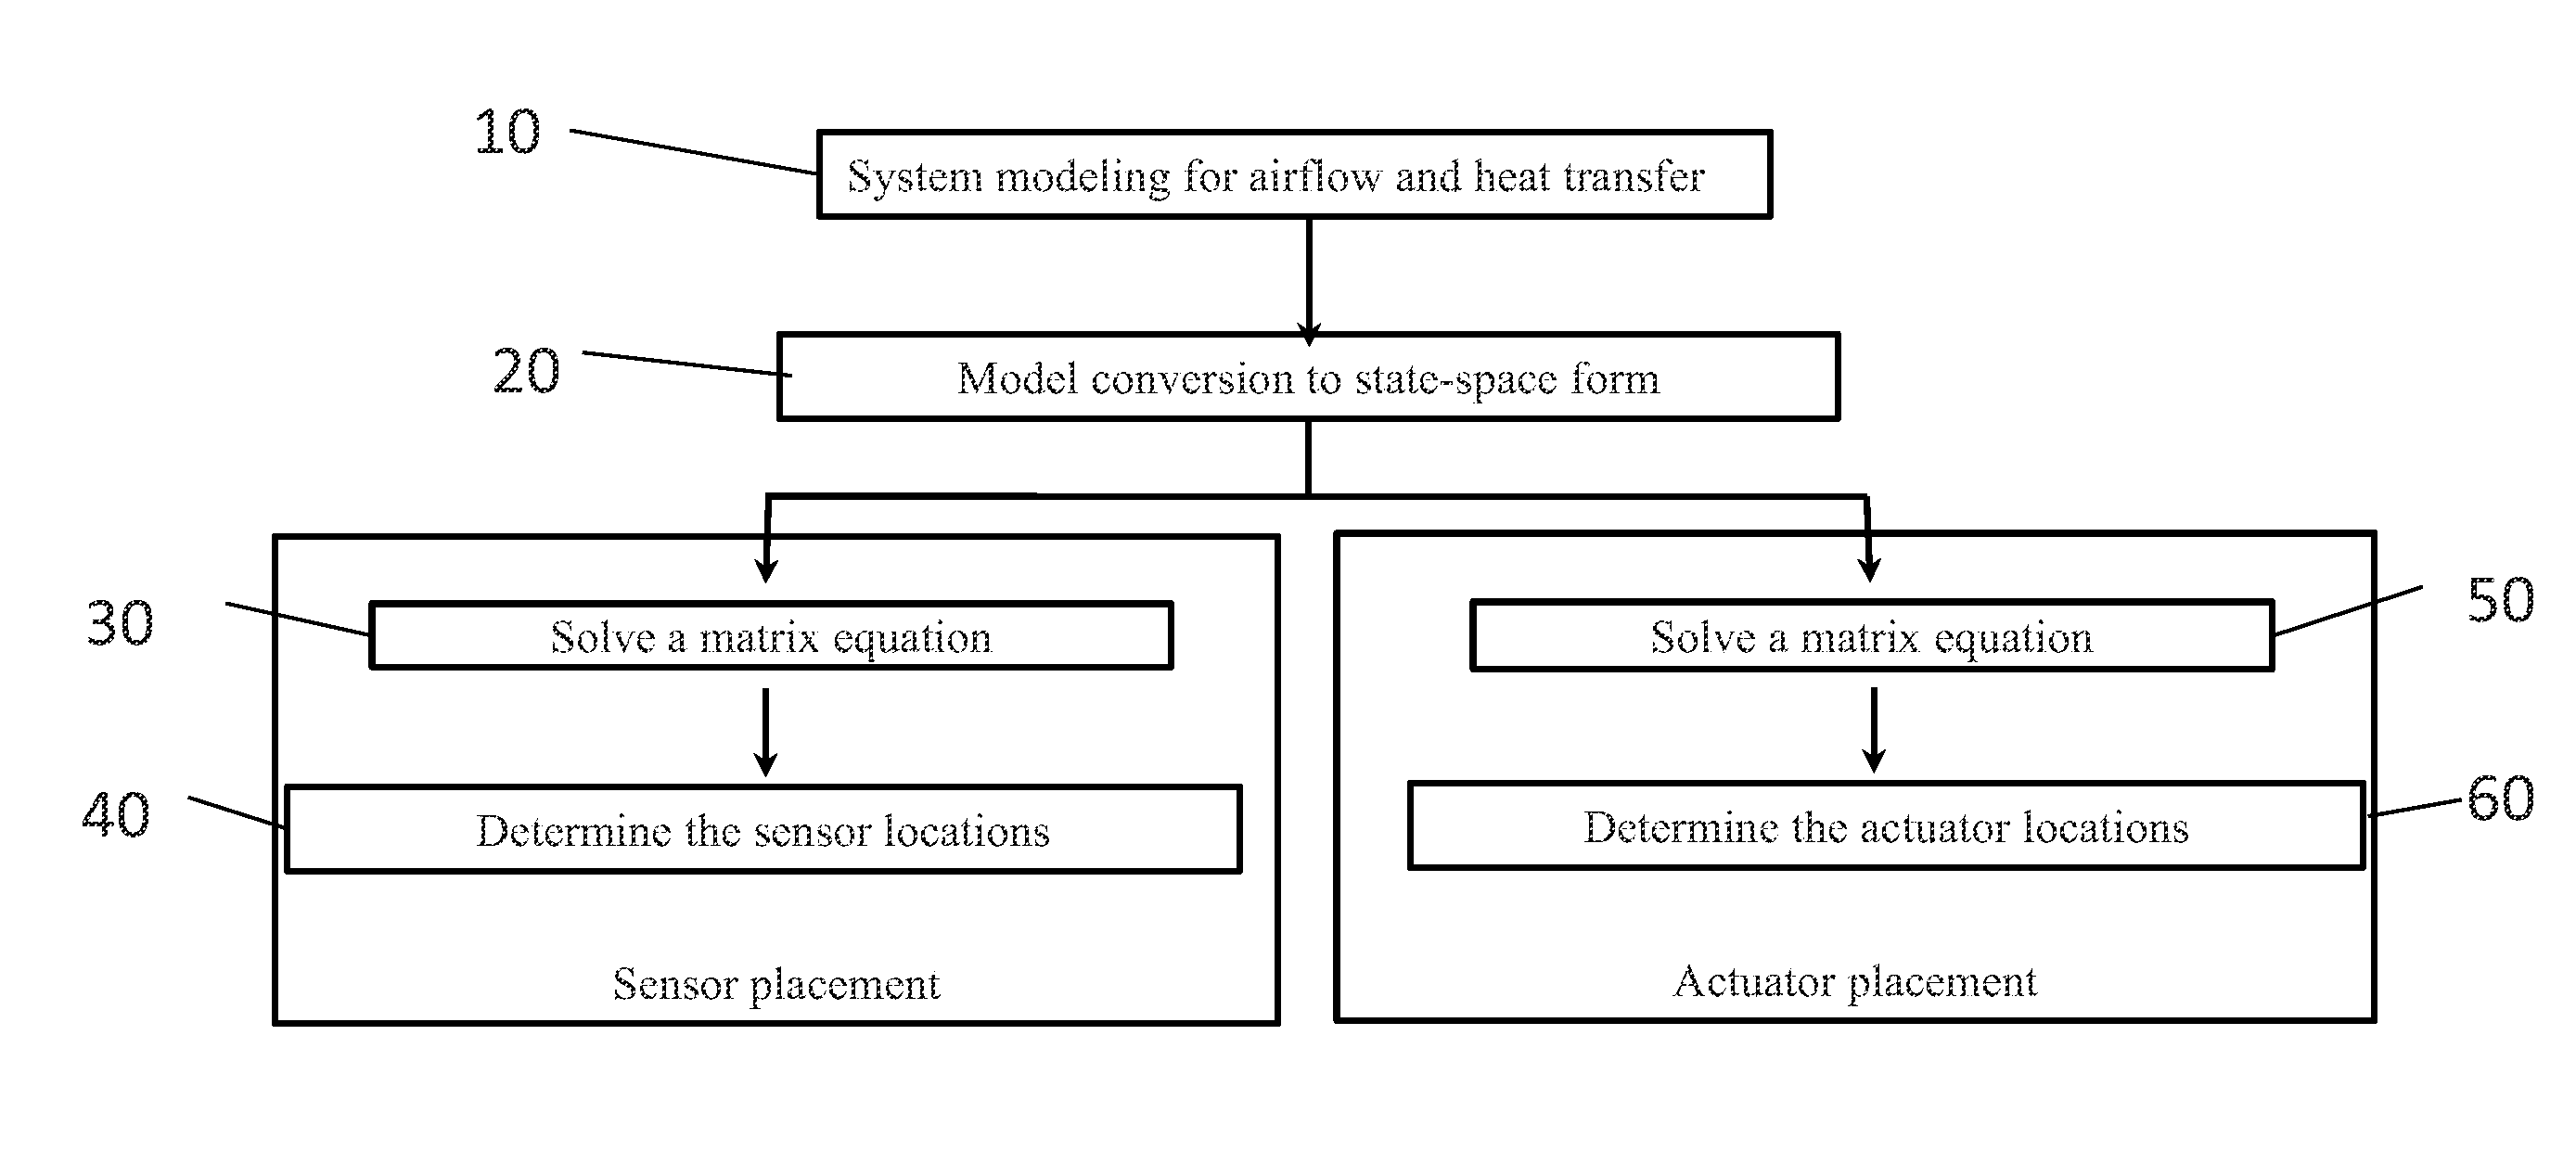
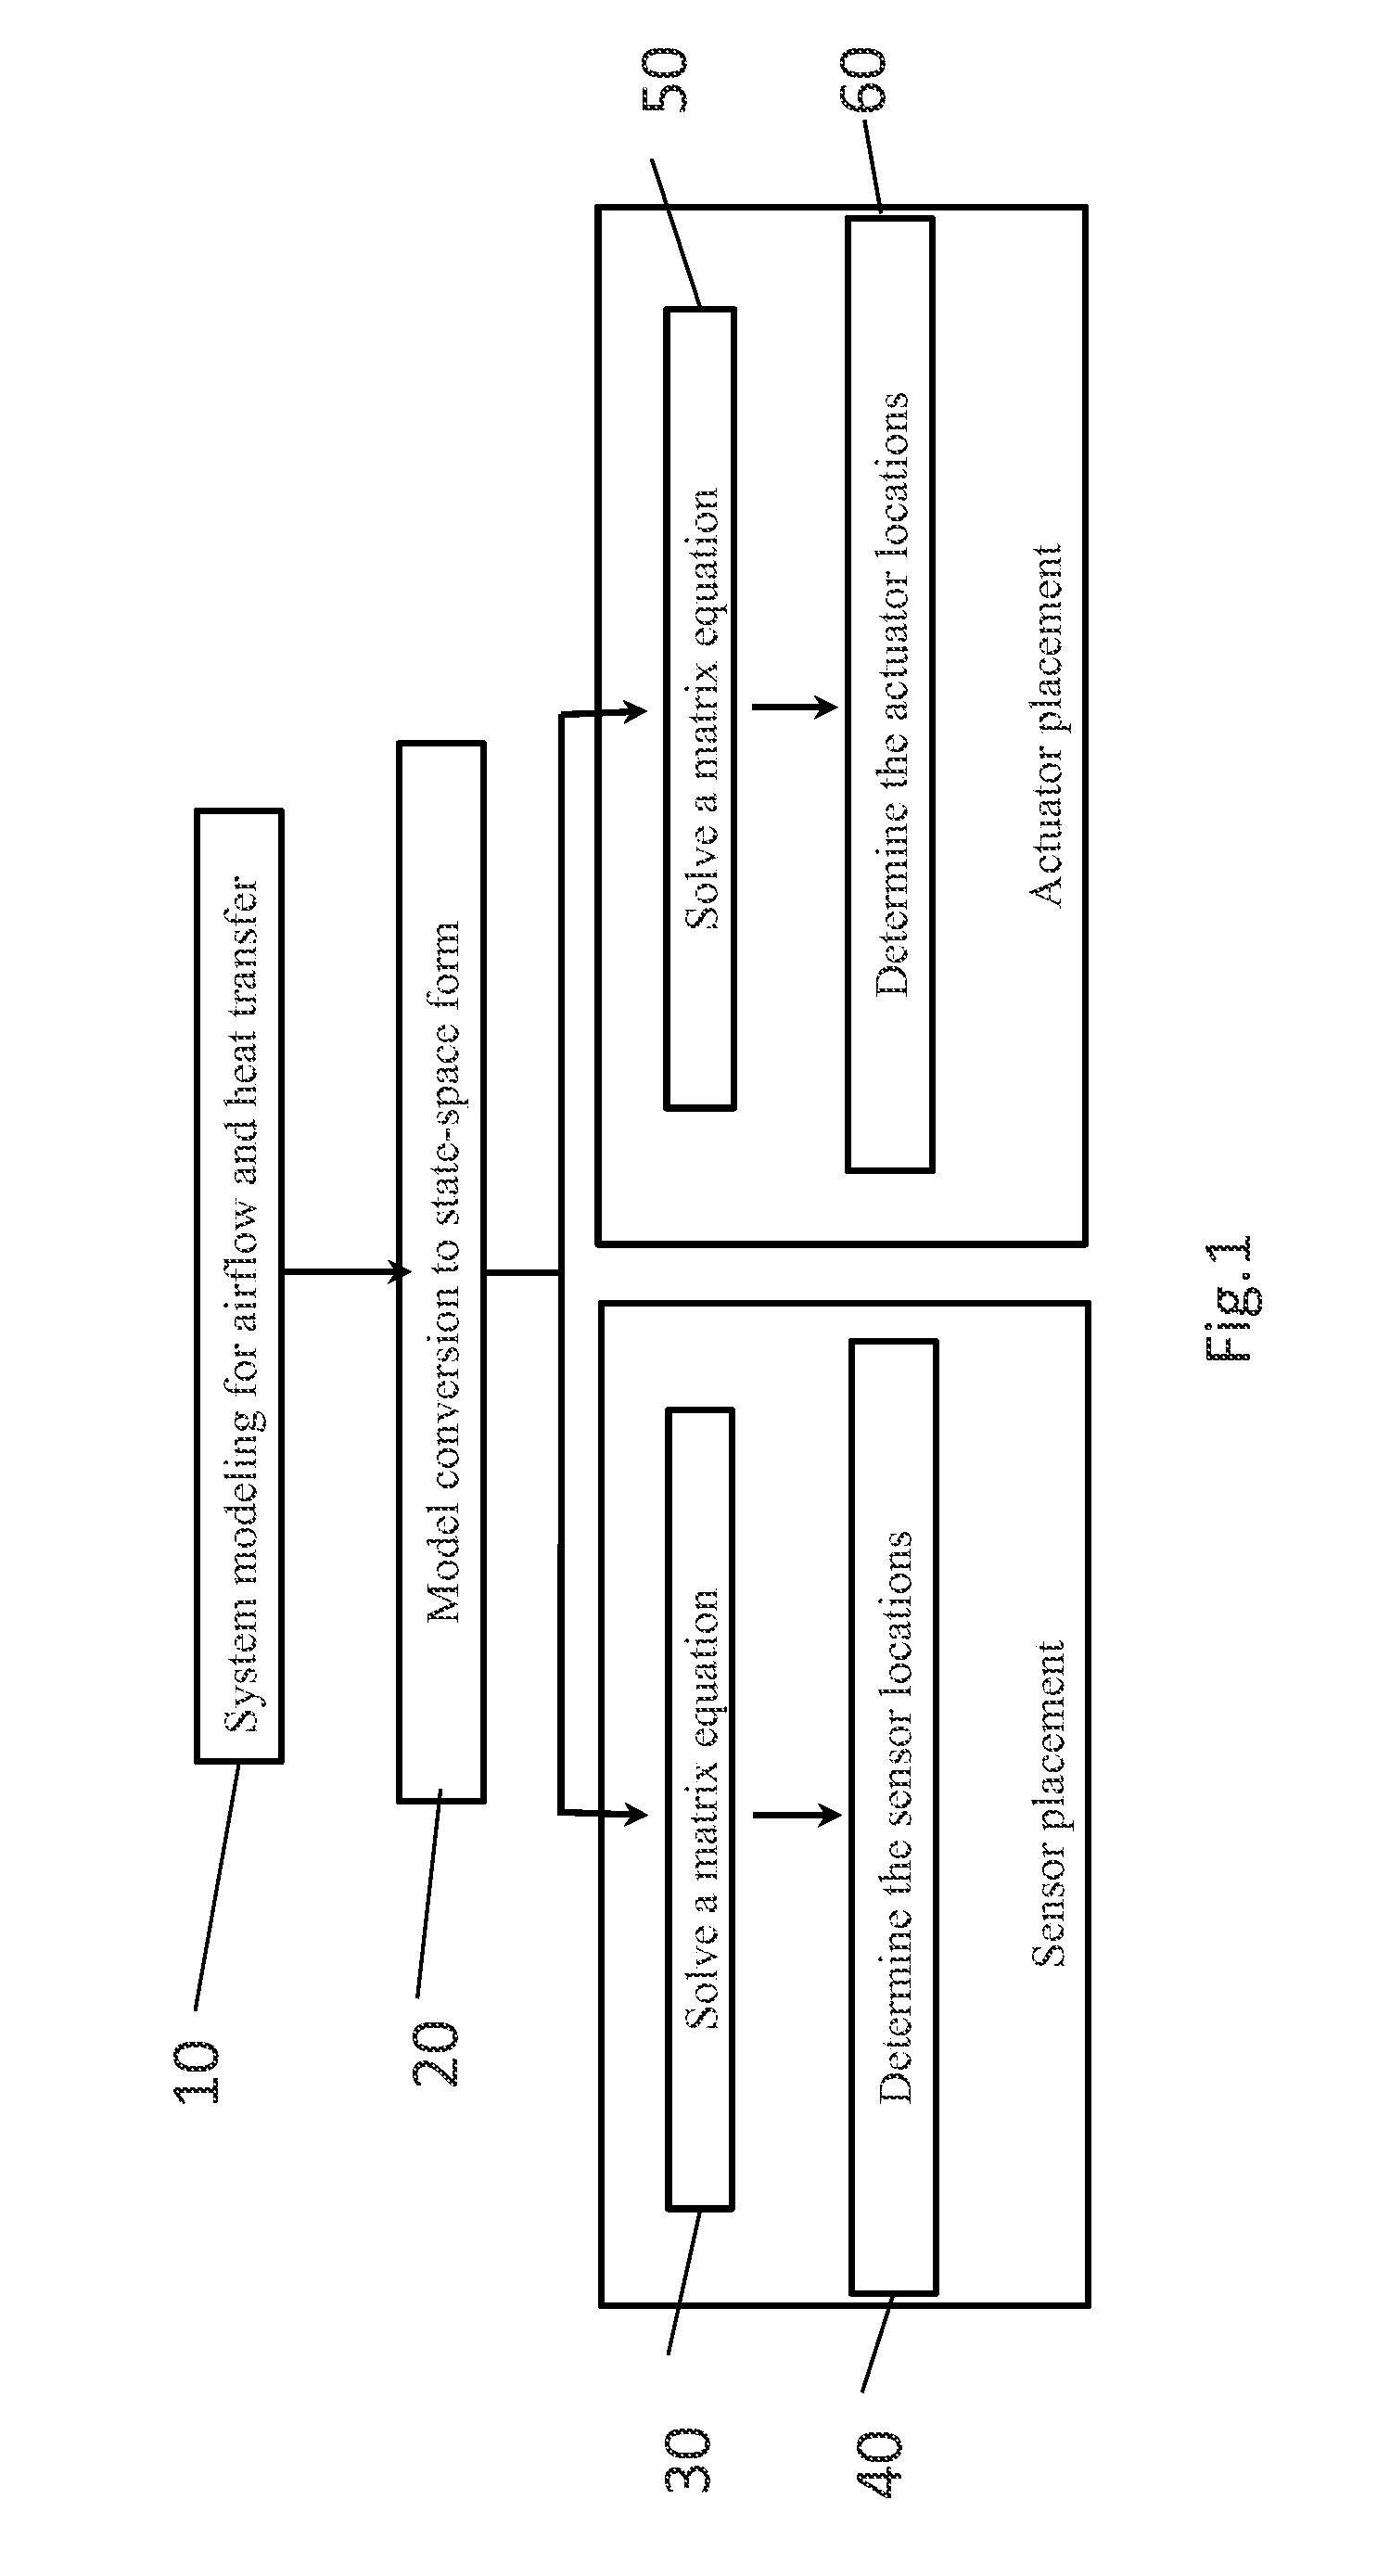
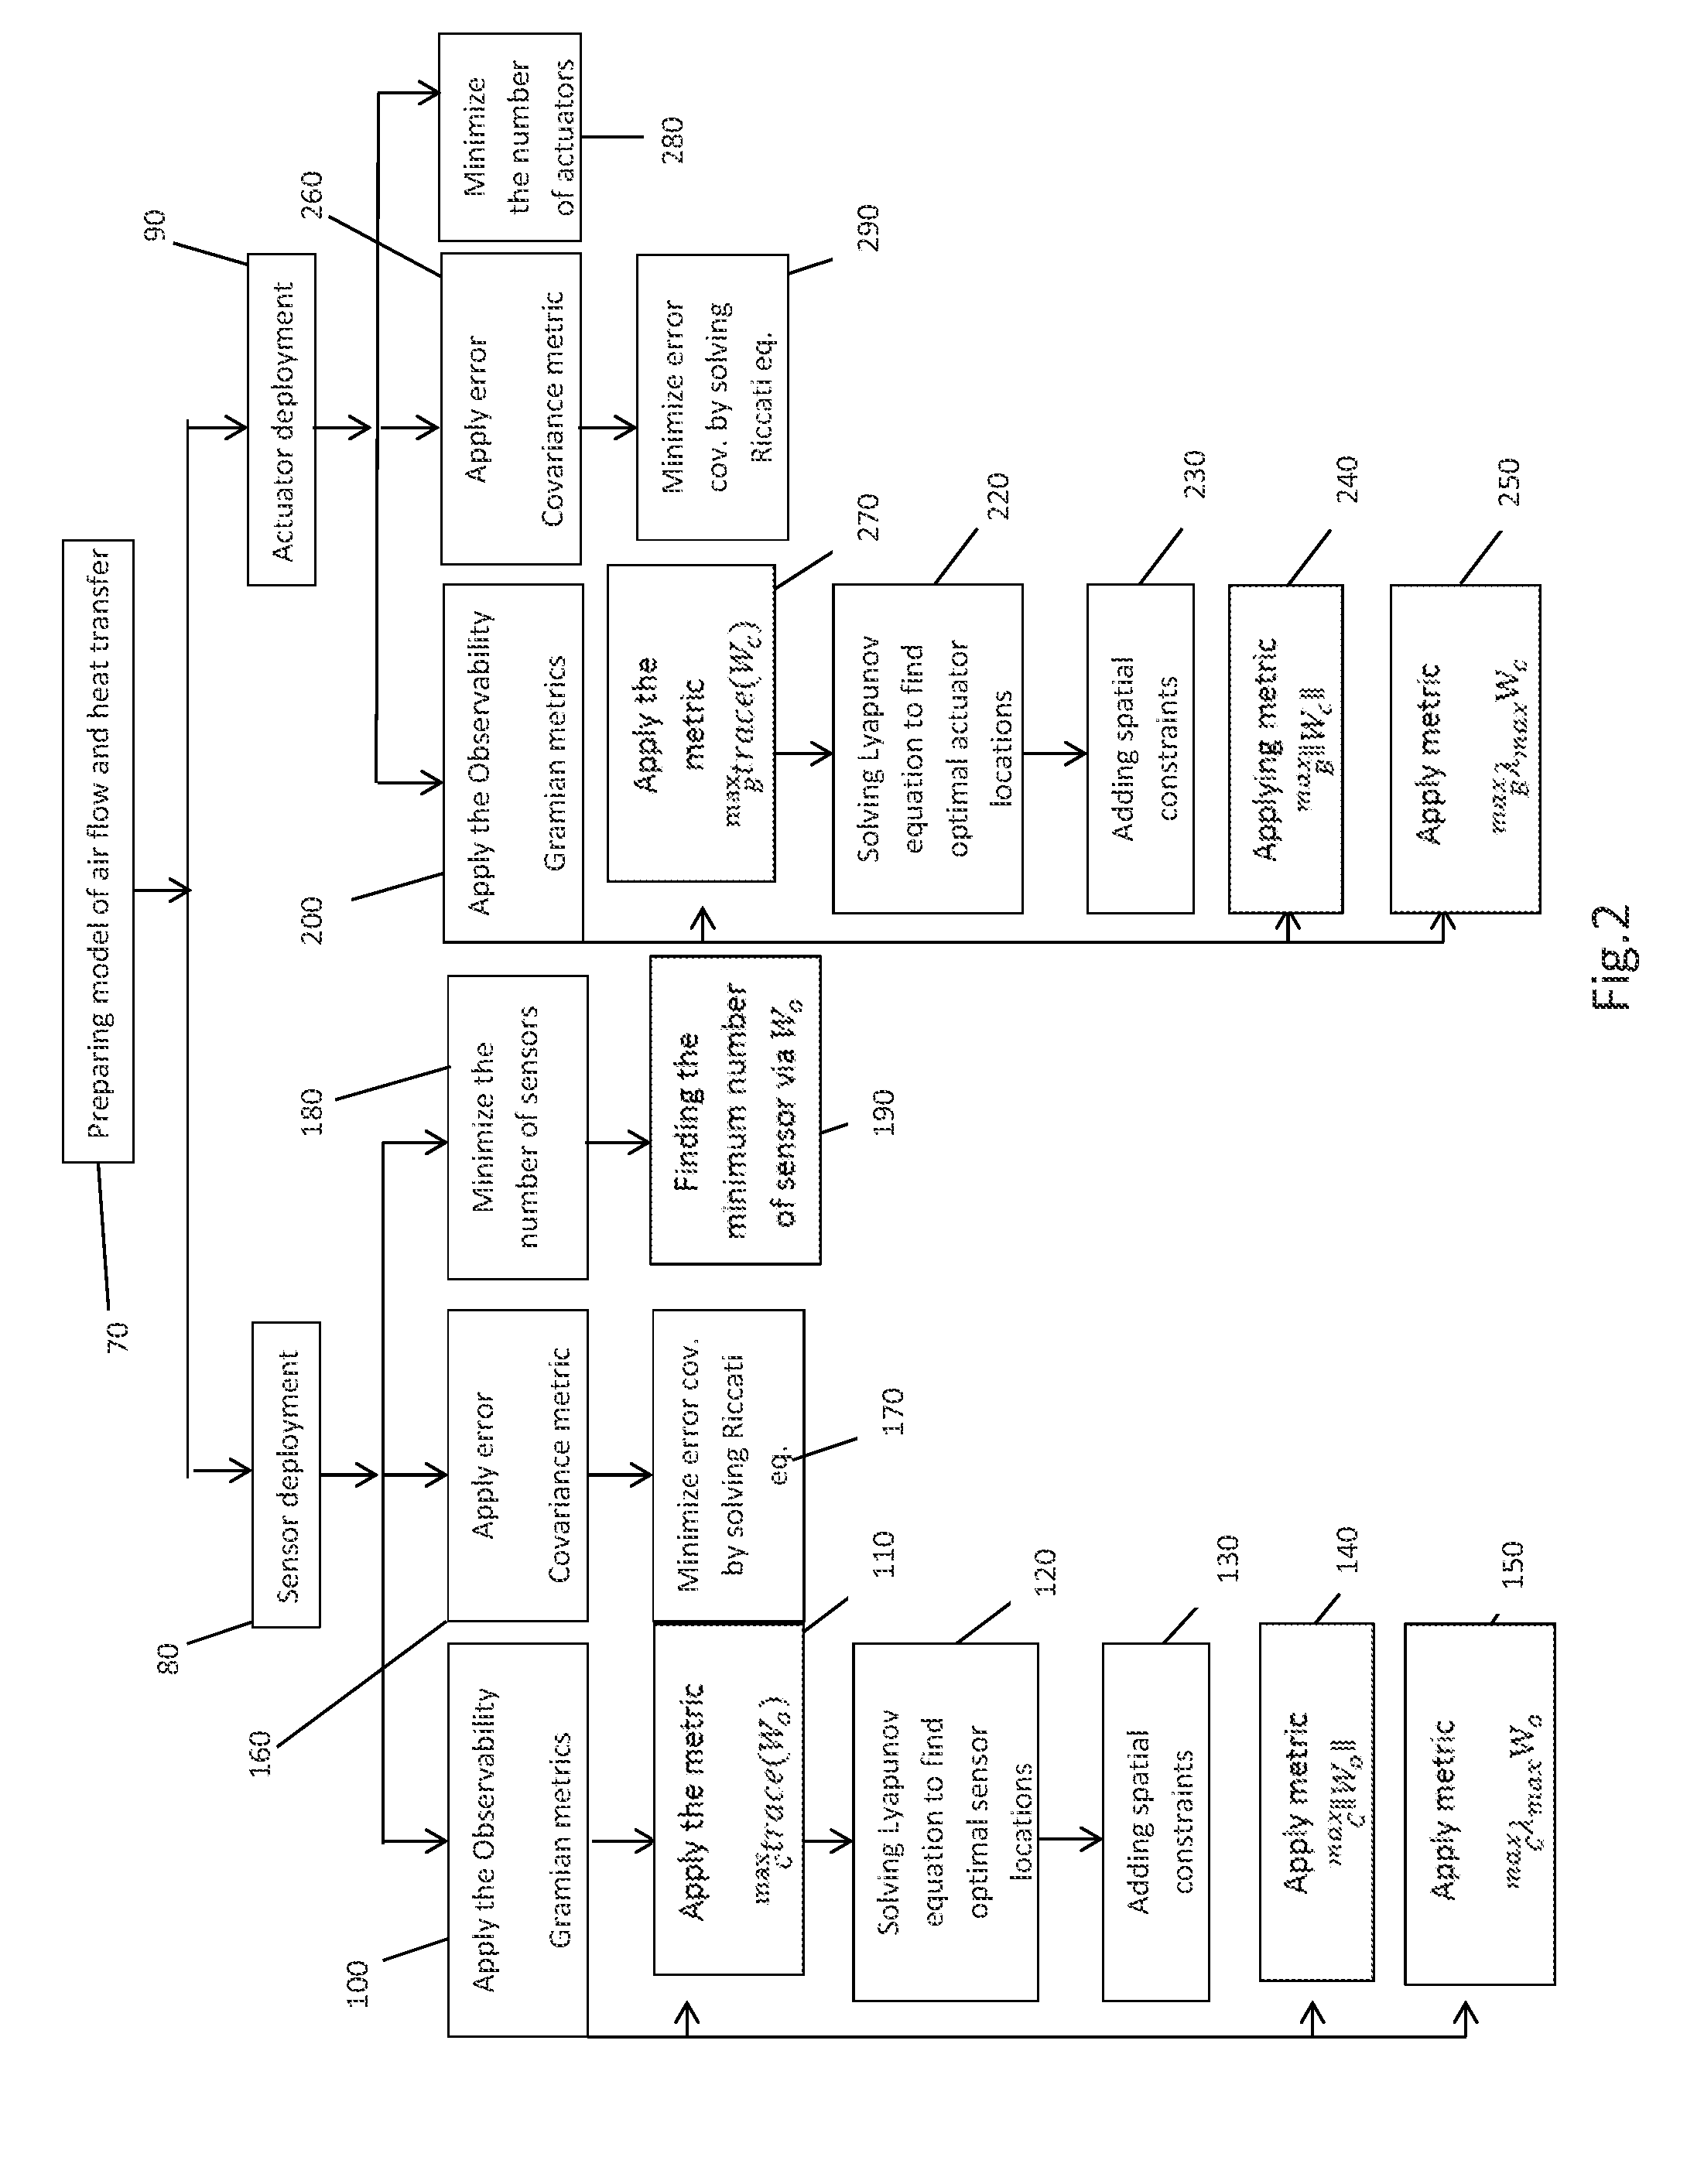
A method of determining the location of actuators and sensors for climate control that includes providing a model of temperature and airflow within a room. A matrix for the placement of sensors is calculated using a Lyapunov equation. A Lyapunov equation includes a matrix for the transition state from the model of temperature and airflow. A trace of the matrix for the placement of sensors is maximized to provide optimum placement of the sensors. A matrix for the placement of actuators within the model is calculated using the Lyapunov equation. A variable for the Lyapunov equation includes the matrix for the transition state obtained from the model of temperature and airflow. A trace of the matrix for the placement of actuators is maximized to provide optimum placement of the actuators within the room.
Owner:NEC LAB AMERICA
Nonlinear control method for suspension transportation system of rotor unmanned aerial vehicle
ActiveCN107765553AGood swing reduction effectPosition/course control in three dimensionsAdaptive controlTransit systemDynamic models
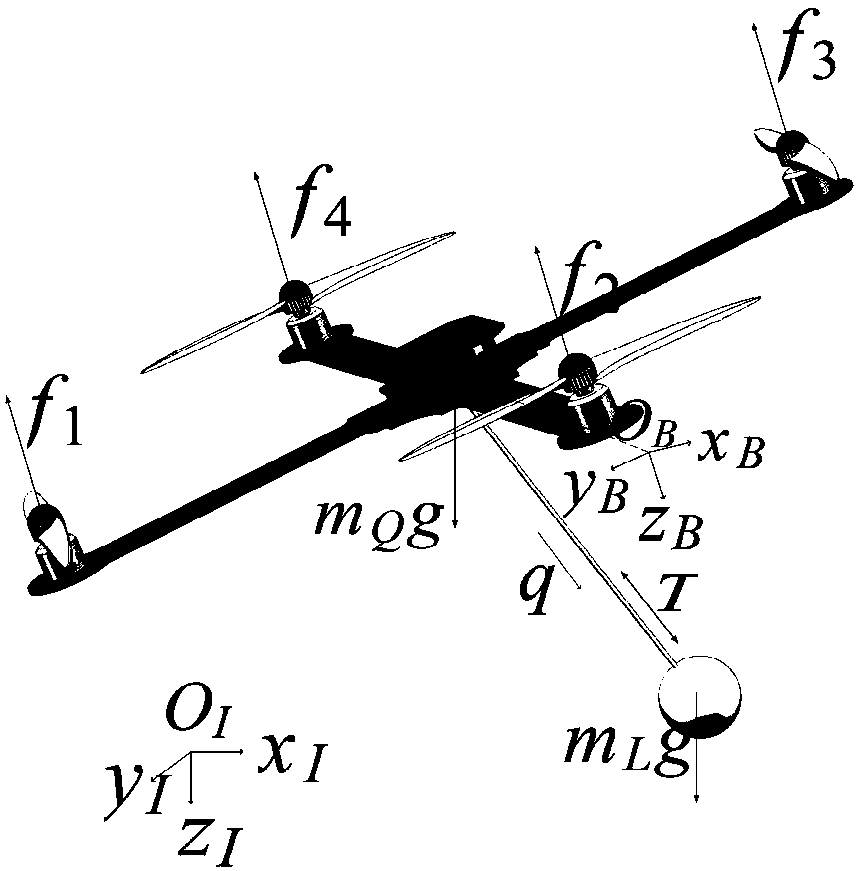
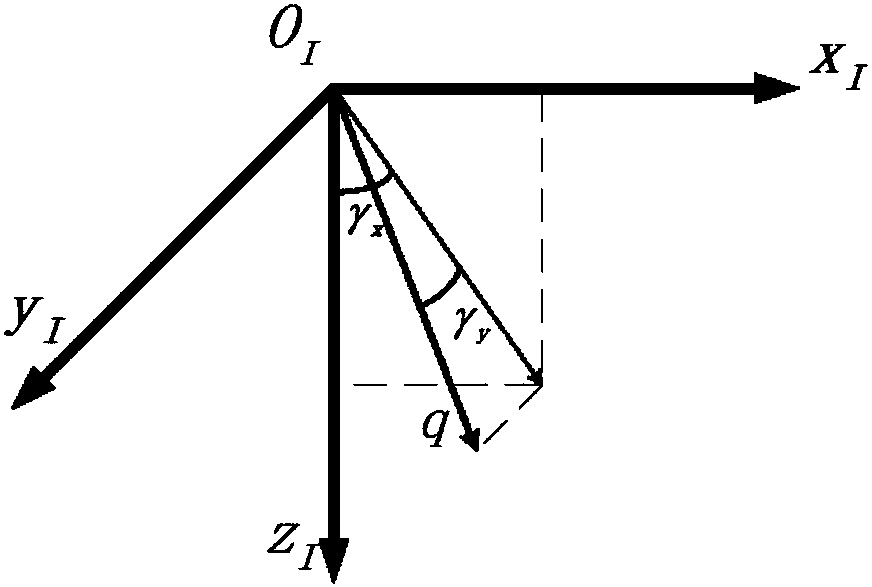
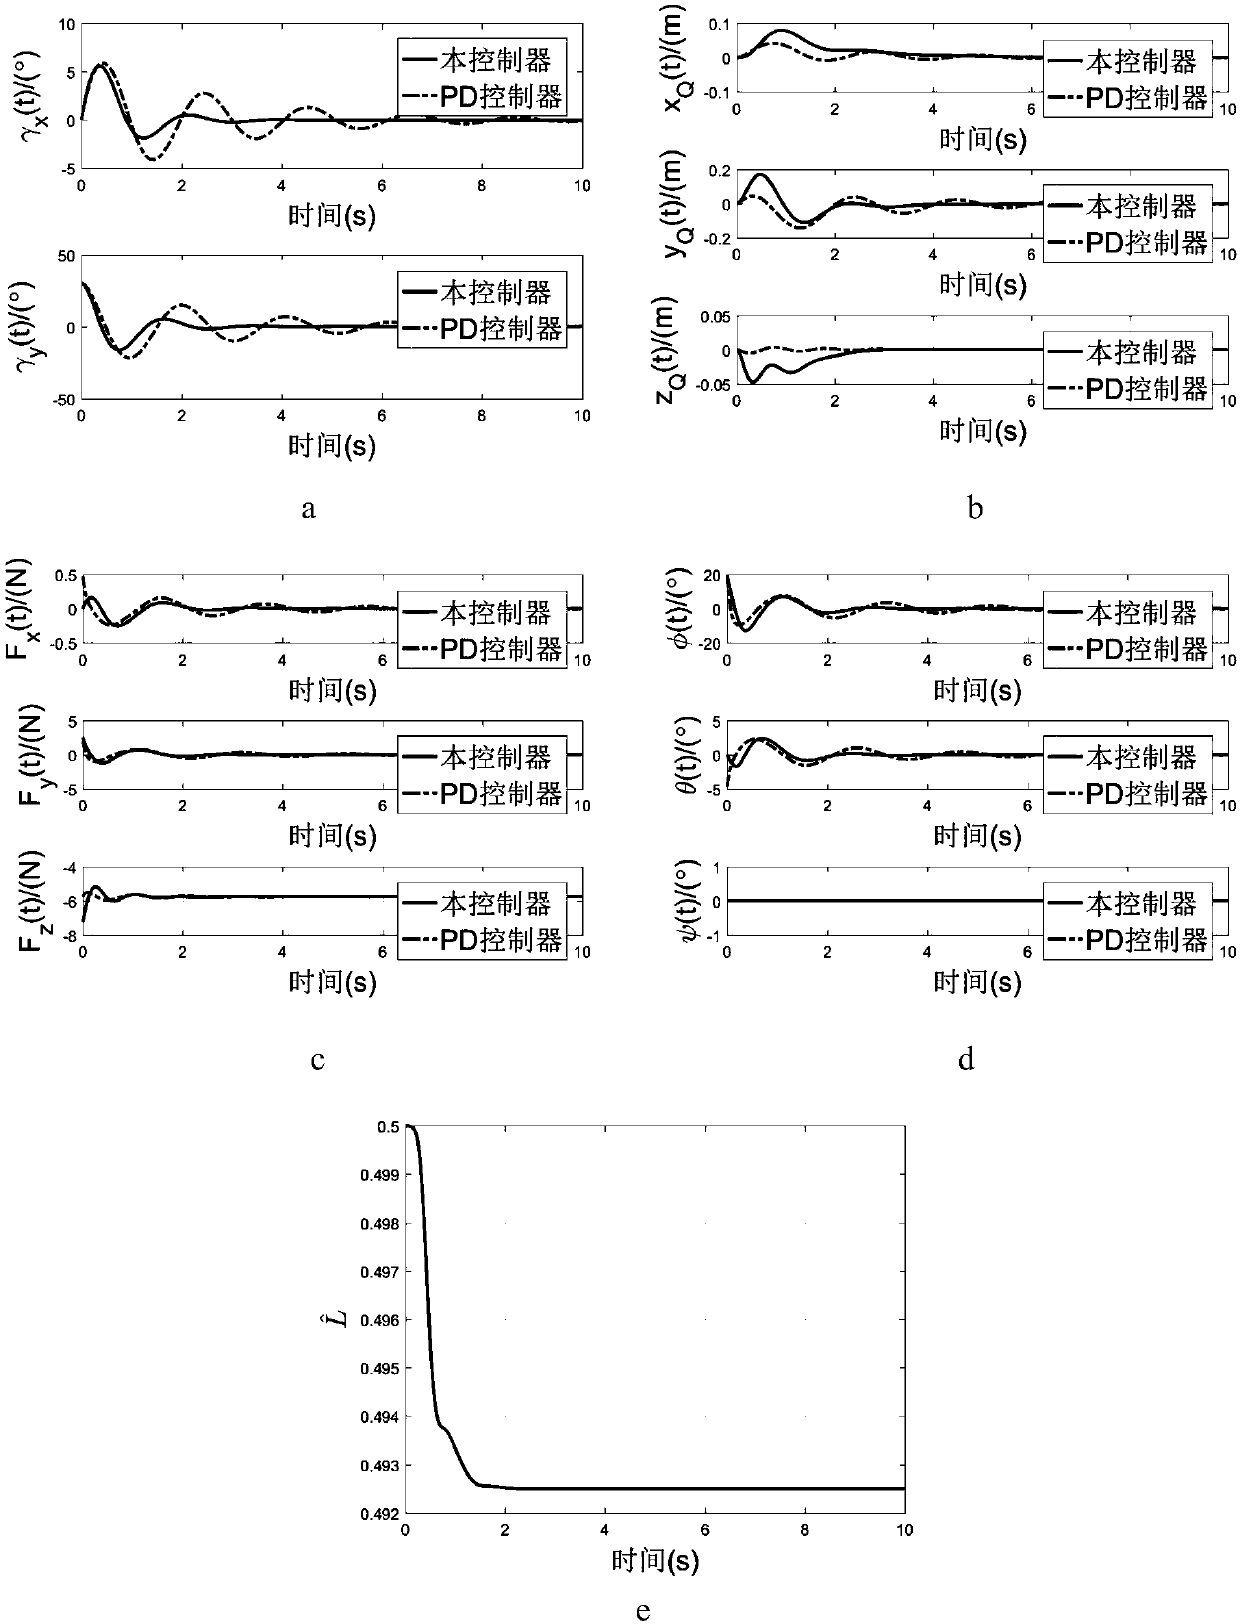
The invention relates to a suspended load transportation flight control technology for a rotor unmanned aerial vehicle, which well suppresses the swinging of a suspended load in the flight while controlling the position of a four-rotor unmanned aerial vehicle under a condition that partial parameters of the system are unknown. The invention adopts a technical scheme that the control method for a suspension flight system of the four-rotor unmanned aerial vehicle based on an energy method comprises the steps of designing a Lyapunov equation based on an energy function method, and thus designinga controller to realize control for the unmanned aerial vehicle. Specifically, firstly stress analysis is respectively performed on the unmanned aerial vehicle and a suspended object in the suspensionflight process of the four-rotor unmanned aerial vehicle so as to acquire a nonlinear dynamic model of the suspension flight process of the four-rotor unmanned aerial vehicle. The nonlinear control method is mainly applied to suspended load transportation flight control of the rotor unmanned aerial vehicle.
Owner:TIANJIN UNIV
Detecting method of rotor position and rotating speed of permanent magnet synchronous motor
InactiveCN107482977ASuppress chatterAccurate estimateElectronic commutation motor controlAC motor controlPermanent magnet synchronous motorPermanent magnet synchronous generator
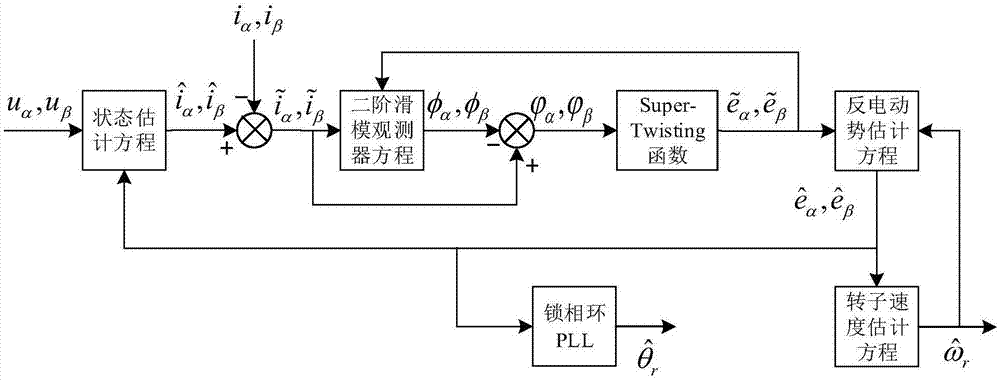
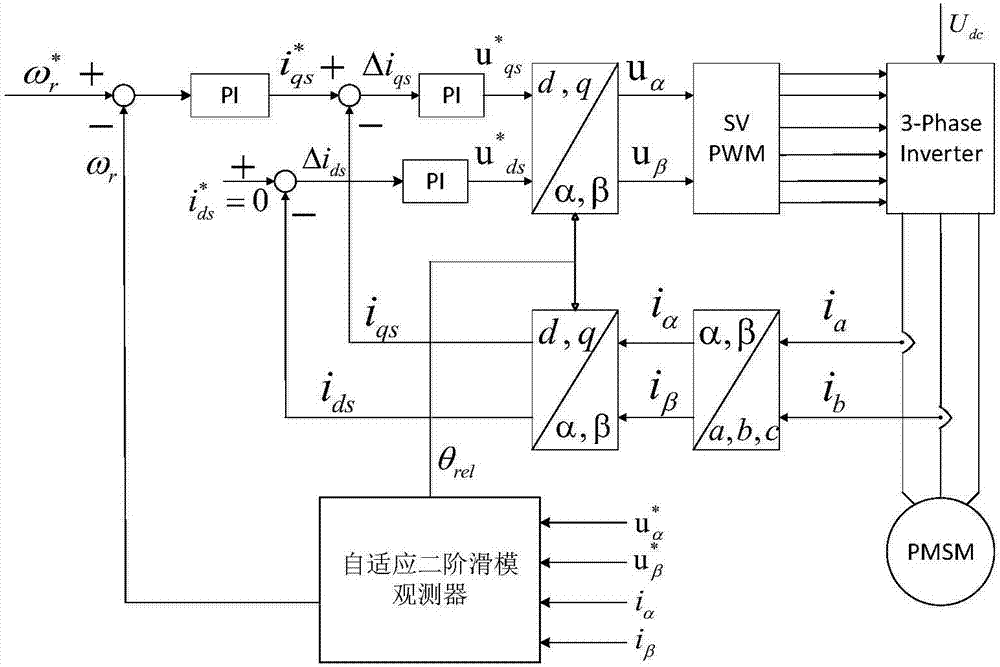
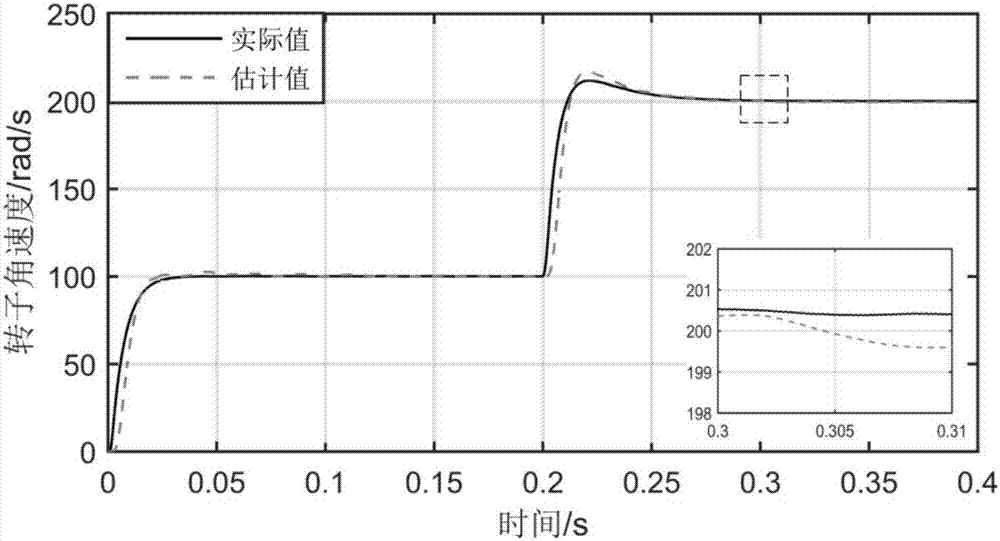
The invention relates to a detecting method of the rotor position and rotating speed of a permanent magnet synchronous motor, and belongs to the field of permanent magnet synchronous motor control. The detecting method includes the following steps that a counter electromotive force equation and a state equation of the permanent magnet synchronous motor are set up; matrix-vector arrangement is carried out on the state equation set up, and a state estimating equation is set up according to the state equation obtained after arrangement to obtain a state error equation; a second-order sliding-mode observer equation is set up according to the state error equation to obtain a counter electromotive force error equation; the sigmoid function is used for replacing the control function signum to correct the counter electromotive force error equation; a counter electromotive force estimating equation is set up according to the counter electromotive force error equation obtained after correction; the counter electromotive force estimating equation is subtracted from the counter electromotive force equation, the Lyapunov equation is used for analyzing stability to obtain and correct a rotor rotating speed estimating equation; rotor position information is extracted through the phase-locked loop technology. A model reference adaption and second-order sliding-mode combined observer is used for estimating counter electromotive force and rotor speed of the permanent magnet synchronous motor and replacing a traditional sliding-mode observer to obtain the rotor speed through counter electromotive force numerical calculation.
Owner:CHONGQING UNIV
Low-orbit flexible satellite attitude tracking control method based on sliding-mode observer
ActiveCN104483973AIncrease factor valueImprove robustnessAttitude controlAdaptive controlTracking modelMode control
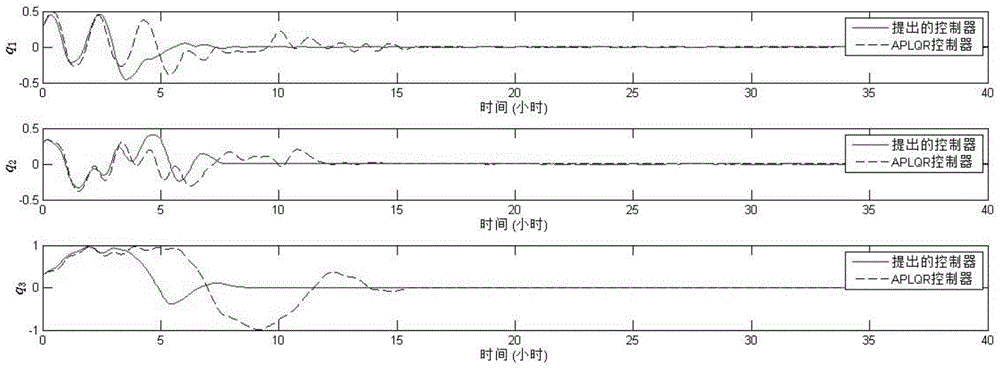
The invention discloses a low-orbit flexible satellite attitude tracking control method based on a sliding-mode observer, relates to a low-orbit flexible satellite attitude tracking control method based on a sliding-mode observer, and aims at solving the problems that an existing low-orbit flexible satellite is low in satellite attitude tracking control accuracy due to relatively large aerodynamic interference torque and vibration of flexile components. The low-orbit flexible satellite attitude tracking control method based on the sliding-mode observer comprises the following steps: building a geocentric inertial coordinate system and a satellite body coordinate system; building a state space expression, and determining an upper bound of an interference signal received by the observer; solving a gain matrix of the observer, a matching matrix of the observer and a Lyapunov equation matrix variable; observing to obtain an estimated mode vibration velocity value of the sliding-mode observer and an estimated mode vibration state value of the sliding-mode observer; rewriting a kinetic equation of a flexible satellite attitude into an error attitude tracking control model; determining a sliding-mode term gain of the control law, and carrying out tracking control on the error attitude tracking model by adopting the siding-mode control law according to measured satellite attitude quaternion, attitude angular velocity information and estimated mode quantity value. The low-orbit flexible satellite attitude tracking control method is applied to satellite attitude tracking control.
Owner:HARBIN INST OF TECH
Magnetic-control bias momentum satellite attitude control method based on periodic Lyapunov equation
ActiveCN104090578AAchieve calmReduce the valueAttitude controlAdaptive controlOptimal controlPerformance index
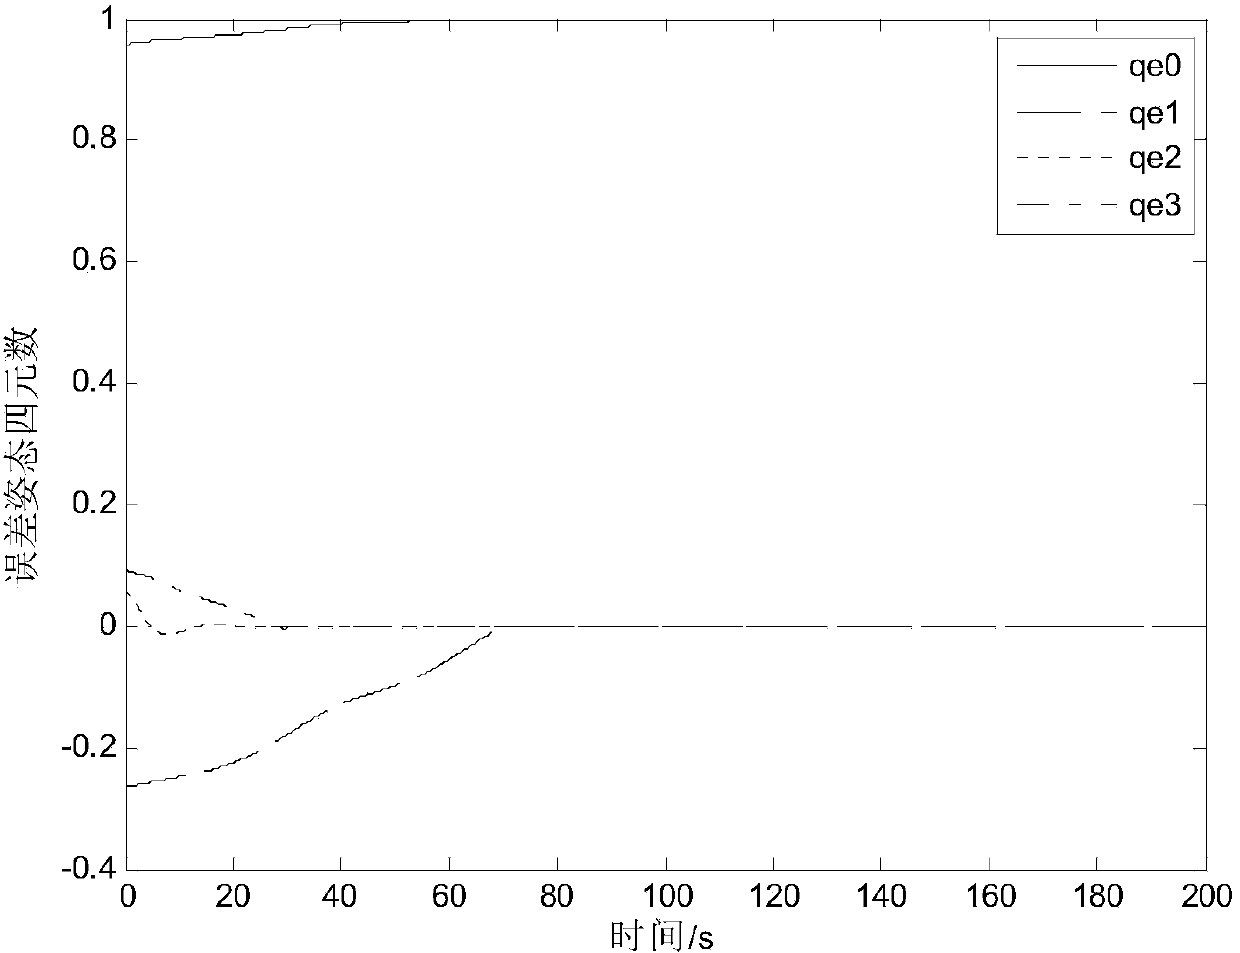
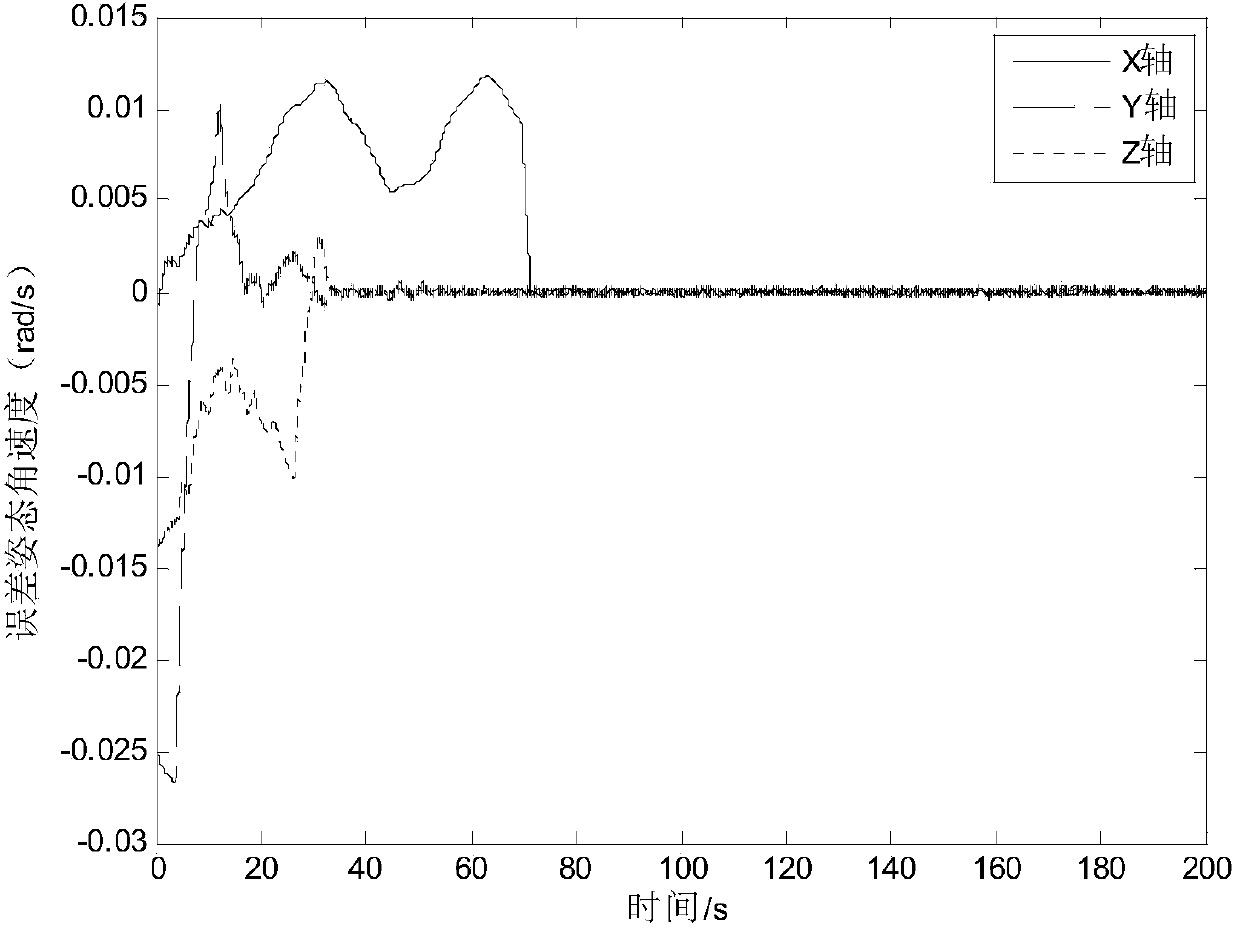
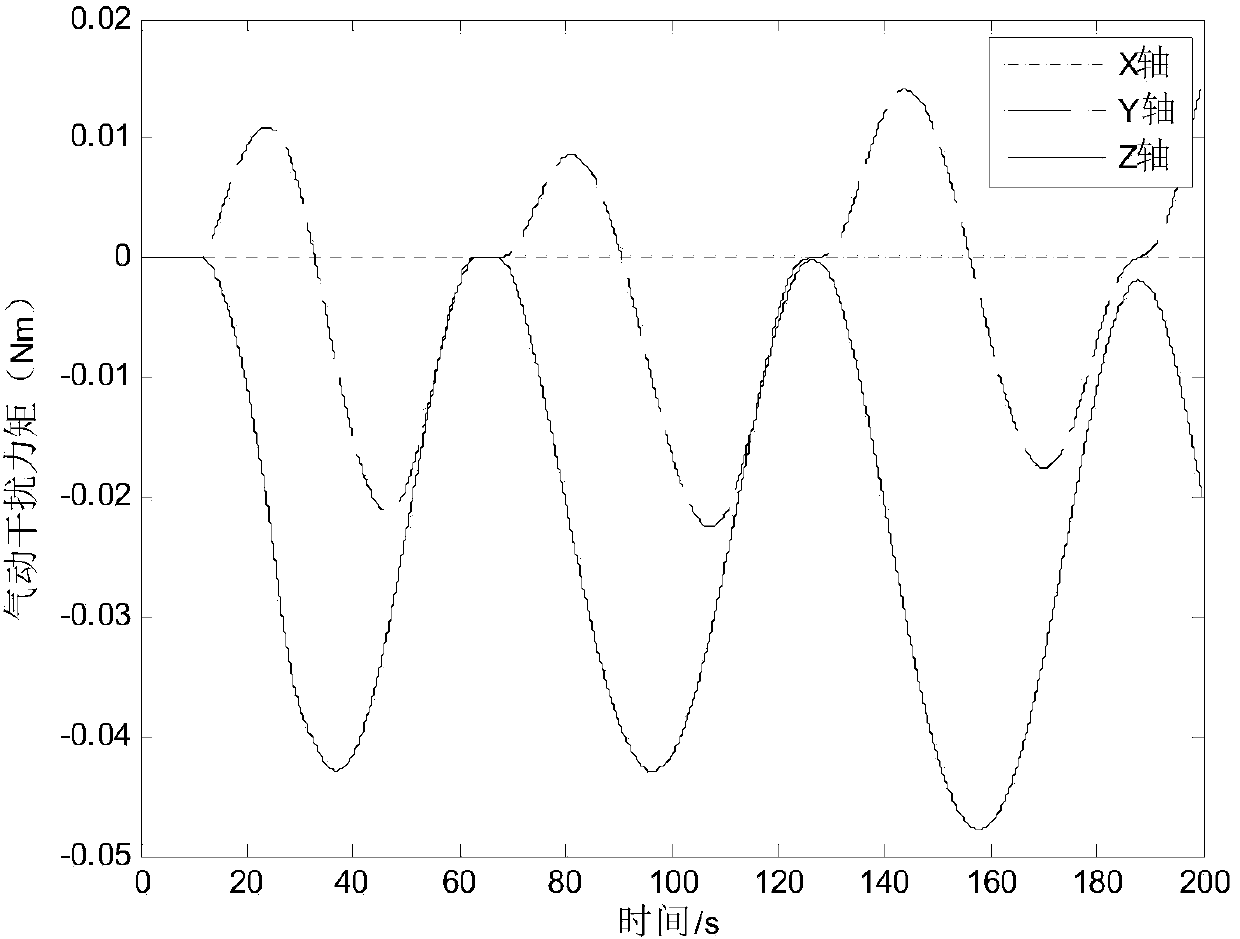
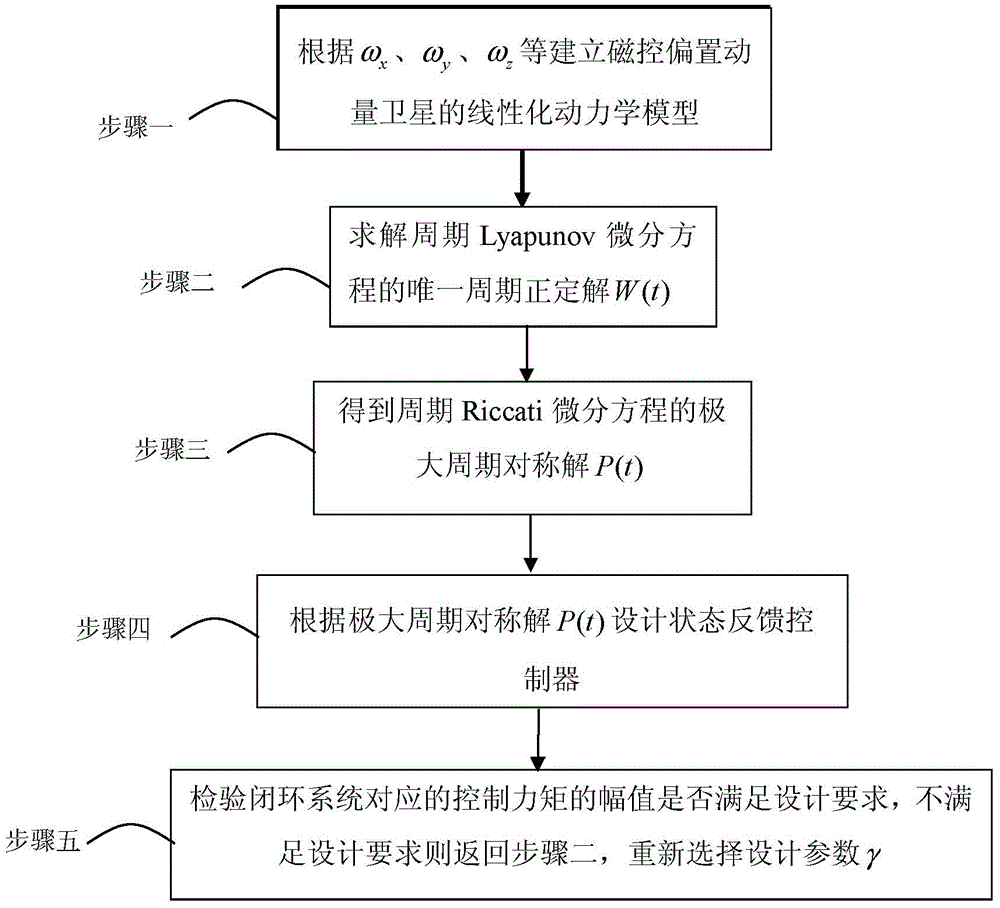
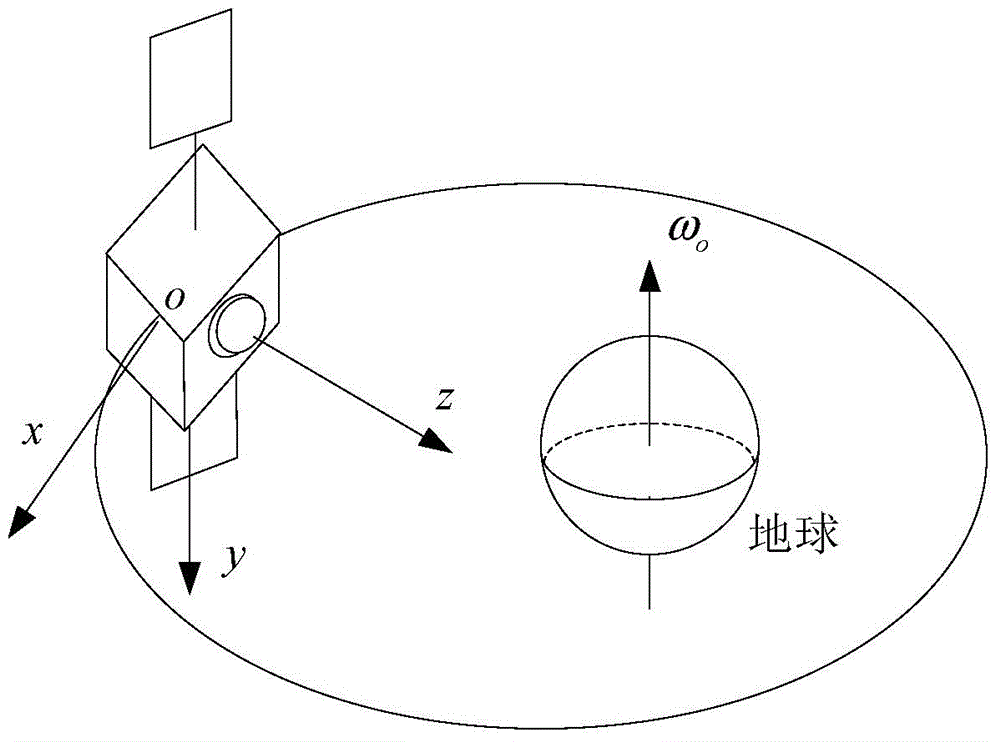
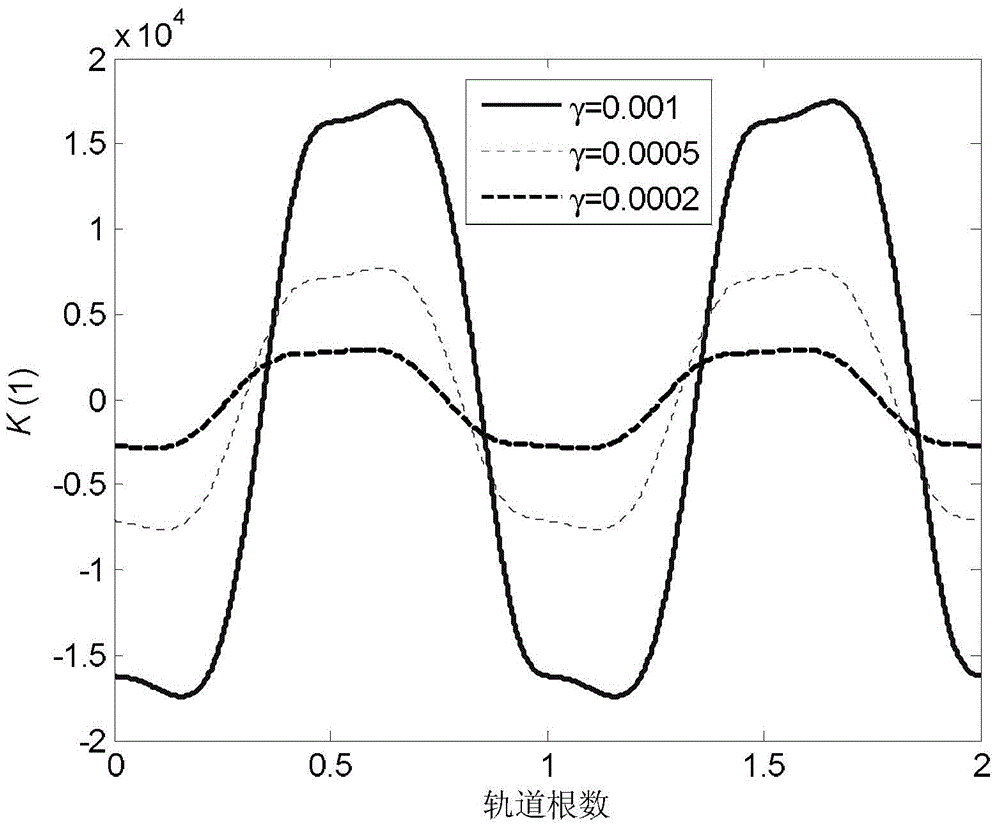
The invention provides a magnetic-control bias momentum satellite attitude control method based on the periodic Lyapunov equation, and relates to a magnetic-control bias momentum satellite attitude control system. The magnetic-control bias momentum satellite attitude control method based on periodic Lyapunov equation solves the problems that magnetic-control moment magnitude is limited, and a quantitative relation between selection of a weighting matrix and a performance index of an actual system is difficult to build in a traditional optimum control design method. The magnetic-control bias momentum satellite attitude control method based on the periodic Lyapunov equation comprises the steps that (1) a linear kinetic model of the magnetic-control bias momentum satellite attitude control system is built, (2) a symmetrical positive definite solution W(t) of the periodic Lyapunov equation is obtained, (3) a symmetrical positive definite solution P(t) of the periodic Riccati differential equation is obtained, (4) a state feedback controller is obtained, and (5) the control effect and the magnitude of control moment are tested. The magnetic-control bias momentum satellite attitude control method based on periodic Lyapunov equation is applied to the field of magnetic-control bias momentum satellite attitude control.
Owner:哈尔滨工业大学人工智能研究院有限公司
Control-limited minisatellite three-axis magnetic moment attitude control method based on algebraic Lyapunov equation
ActiveCN104881036AGuaranteed global asymptotic stabilityAttitude controlSystem matrixAlgebraic equation
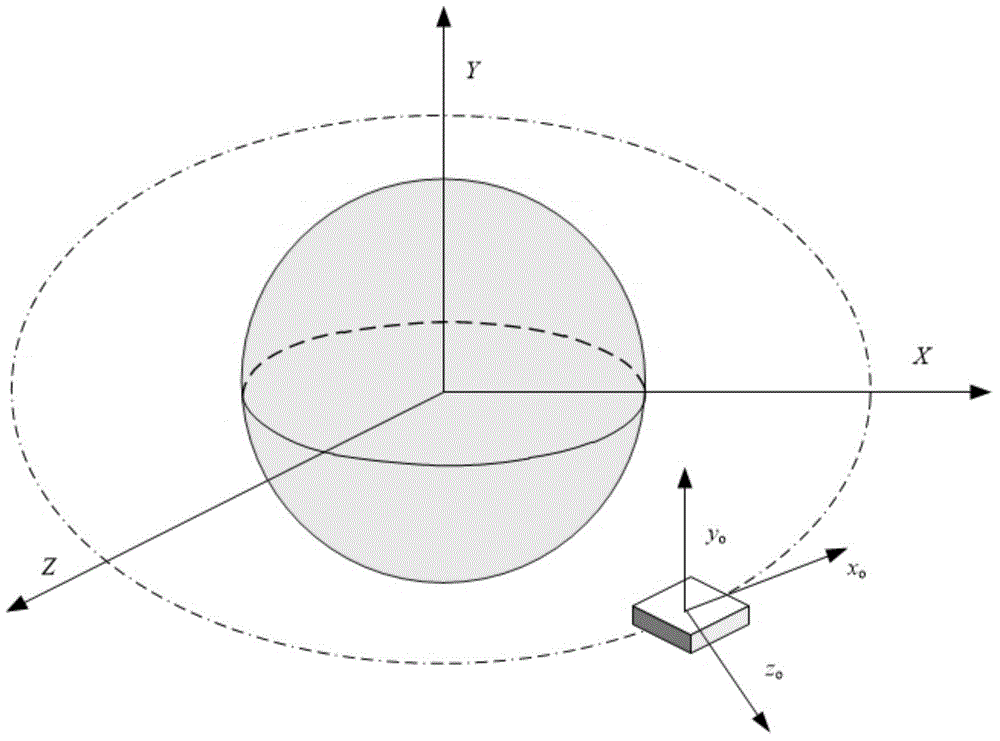
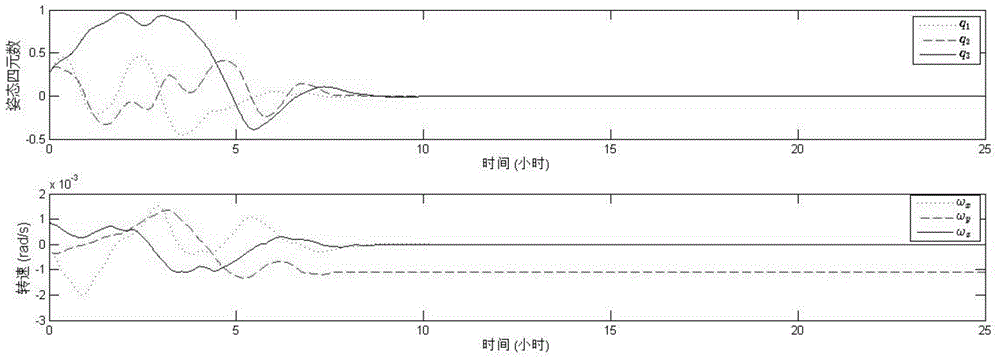
Provided is a control-limited minisatellite three-axis magnetic moment attitude control method based on an algebraic Lyapunov equation. The invention relates to a control-limited minisatellite three-axis magnetic moment attitude control method based on an algebraic Lyapunov equation. The method is used to realize global stability of a minisatellite three-axis magnetic moment attitude control under control-limited conditions. The method comprises: step 1, establishing attitude kinematics and attitude kinetic models of control-limited minisatellite three-axis magnetic moment attitude control, to obtain a state-space equation; step 2, solving explicit solution P0 of the algebraic Lyapunov equation A<T>P0+P0A=-D<T>D, wherein A is a system matrix, D is a matrix in arbitrary dimensions, the system matrix A being critical stable or Lyapunov stable, ensuring the algebraic Lyapunov equation have a positive definite solution P0; step 3, and through the positive definite solution P0 of the algebraic Lyapunov equation, designing linear feedback control law under explicit control-limited conditions. The method is applied in the field of satellite control.
Owner:哈尔滨工业大学人工智能研究院有限公司
Time-varying feedback finite-time stabilization method of control limited spacecraft rendezvous control system
ActiveCN110727199AGuaranteed Rendezvous MissionFast convergenceAdaptive controlSolution of equationsFeedback controller
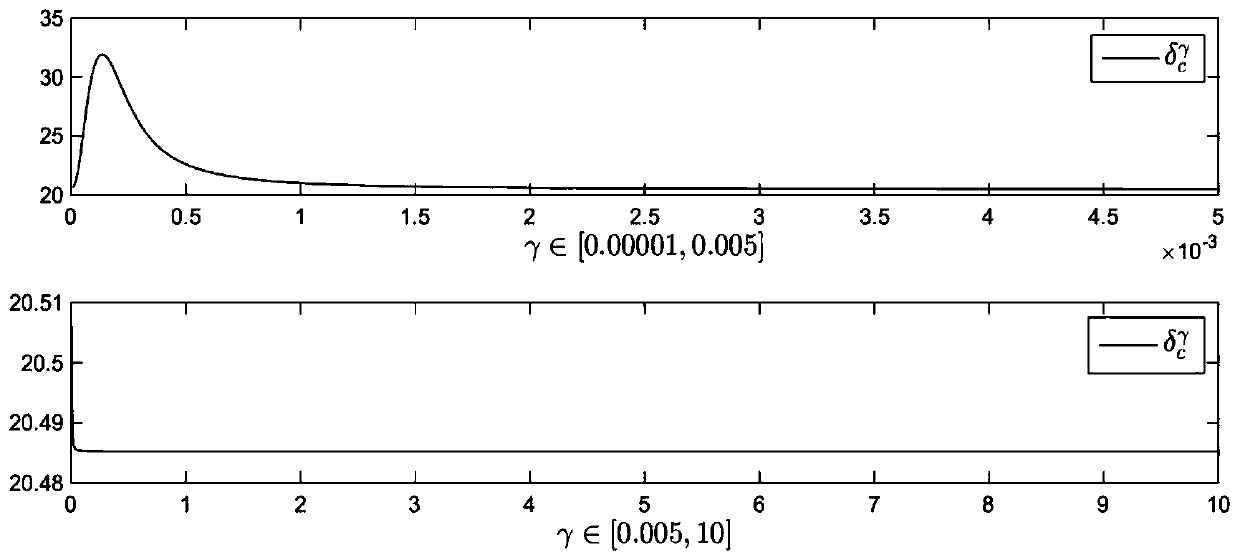
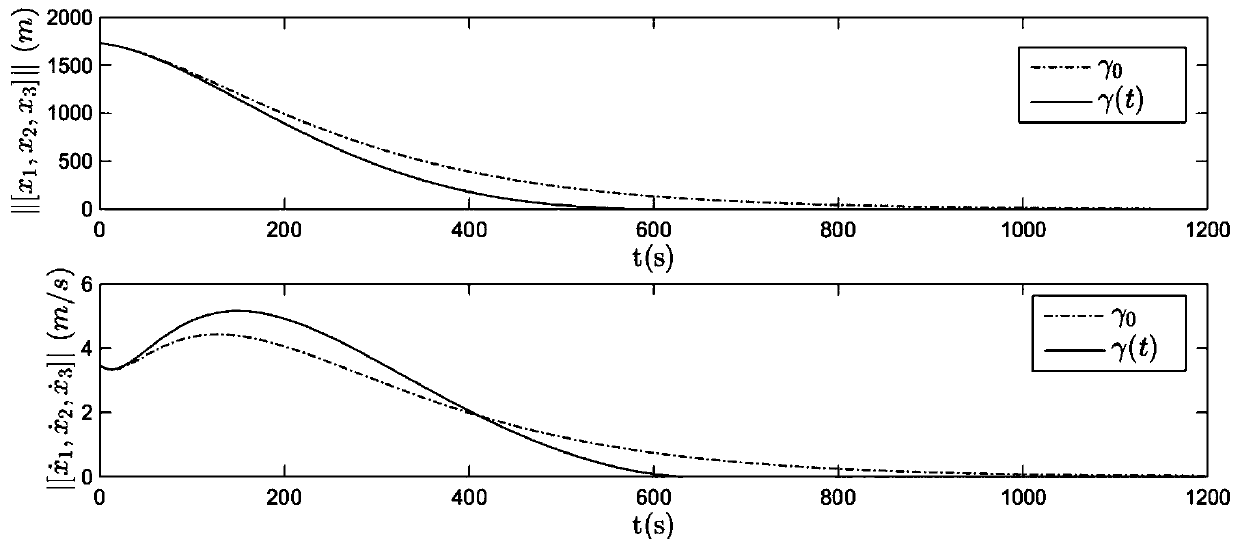
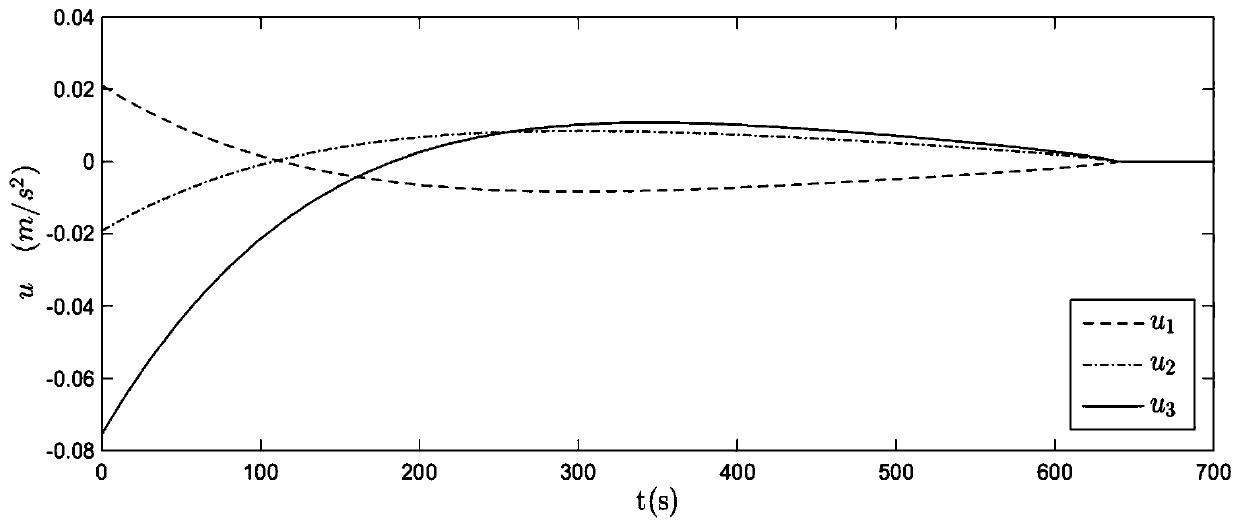
The invention relates to a time-varying feedback finite-time stabilization method of a control limited spacecraft rendezvous control system. The stabilization method comprises the steps of: (1), establishing an orbital dynamics model of the control limited spacecraft rendezvous control system, and obtaining a state-space equation; (2), establishing a parametric Lyapunov equation, analyzing the property thereof, according to the positive definite solution P(gamma) of the parametric Lyapunov equation, designing an explicit linear time-varying feedback control law in a control limited condition,namely, designing a state feedback controller of the control limited spacecraft rendezvous control system; and (3), designing controller parameters by constructing an explicit Lyapunov function and utilizing the property of the parametric Lyapunov equation solution, and ensuring that a tracking spacecraft and a target spacecraft complete a rendezvous task in limited time. By means of the time-varying feedback finite-time stabilization method of the control limited spacecraft rendezvous control system in the invention, limited time stabilization of the spacecraft rendezvous control system in the control limited condition can be realized.
Owner:HARBIN INST OF TECH
Wind-power-generation containing two-region interconnected power grid automatic generation control optimization method
InactiveCN107979113AImprove dynamic adaptabilityImprove coordinationSingle network parallel feeding arrangementsPower oscillations reduction/preventionClosed loopControl zone
The invention relates to a wind-power-generation-containing two-region interconnected power grid automatic generation control optimization method. The method comprises the steps of: establishing an automatic generation control space state model, wherein the model is a two-region interconnected system including hydroelectric power, a small fossil power plant and wind power; according to the established space state model, constructing a new cost function; forming a control variable by an output variable and an output feedback gain matrix so as to determine an input variable; in a closed-loop system, constructing a Lyapunov function to obtain a Lyapunov equation; and based on the Lyapunov equation, deriving a Hamilton function, and obtaining optimal values of corresponding parameters so as toobtain an automatic generation control optimization result of the established model. A control strategy disclosed by the invention has good dynamic adaptability and can reinforce coordination among aplurality of control regions. The invention solves the problem of frequency fluctuation of a power system, which is caused by ever-increasing installed capacity of wind power and inherent randomnessand fluctuation of the installed capacity of wind power.
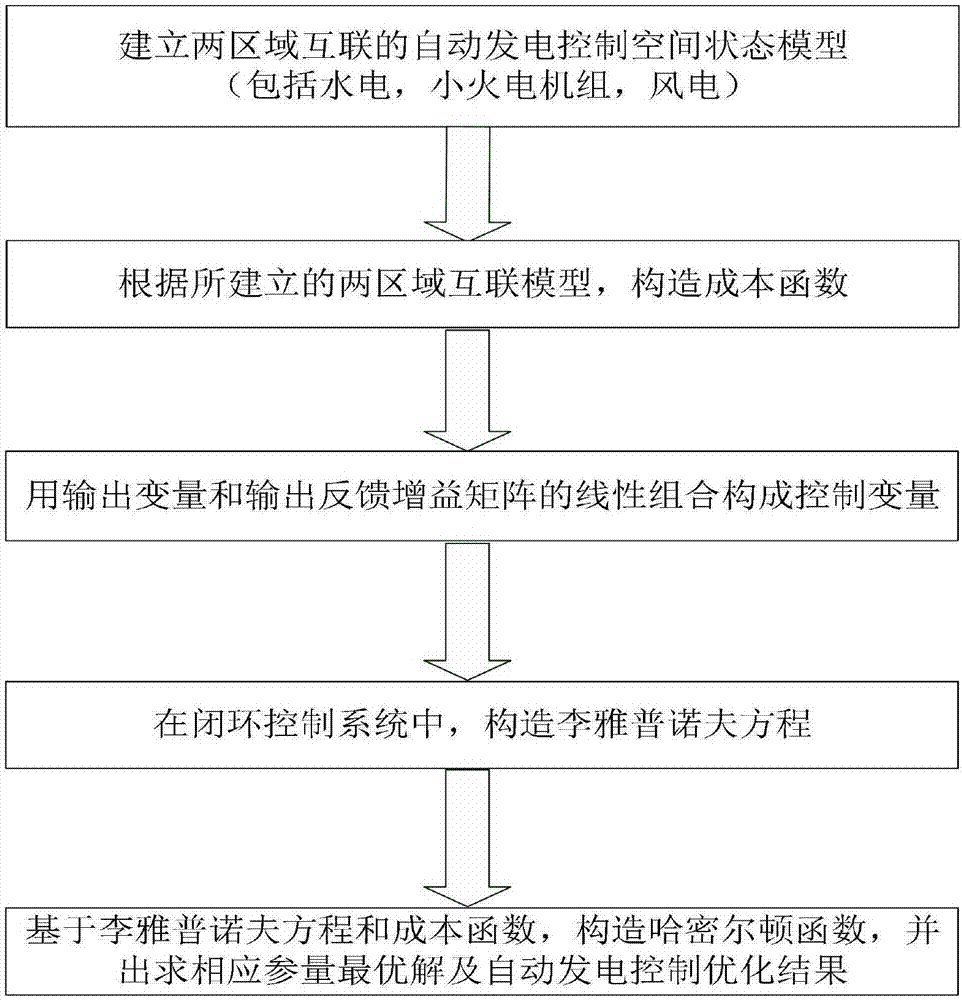
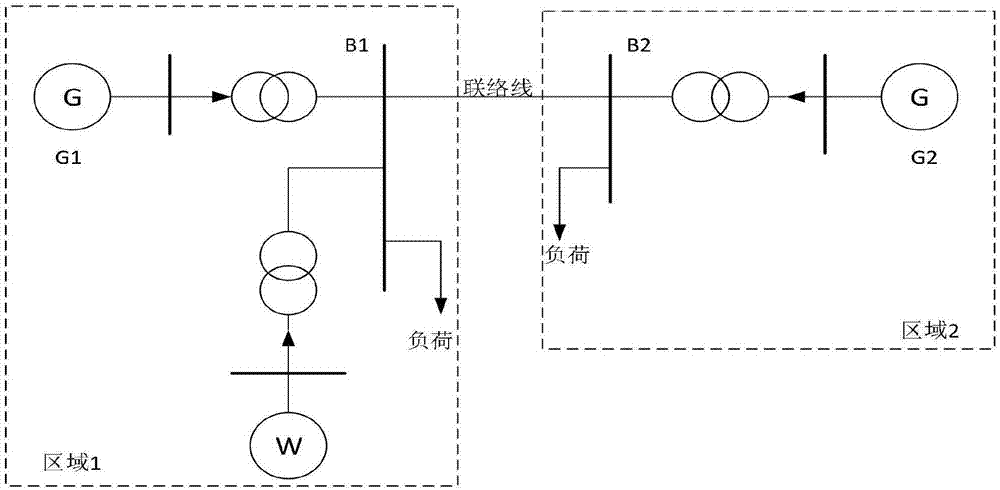
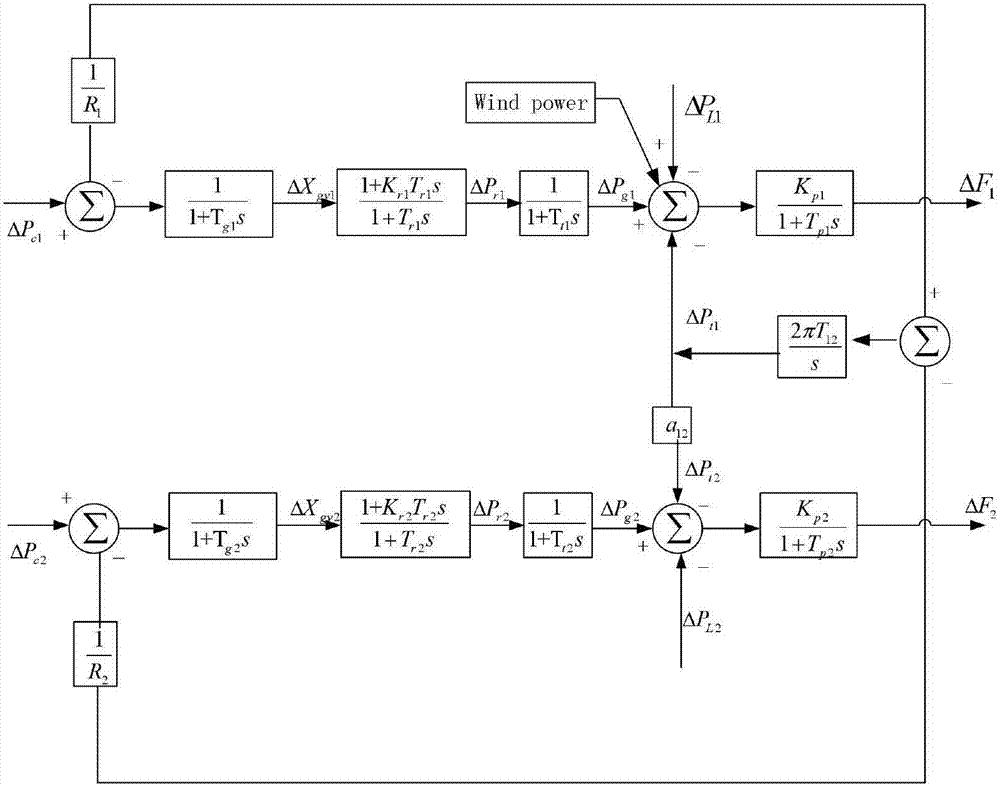
Owner:YUNNAN POWER GRID
Design method for data-driven posture controller of non-cooperative target assembled spacecraft
ActiveCN108804846AStable Linear Globally Stabilized Approximate Optimal ControllerStable Linear Global StabilizationCosmonautic vehiclesCosmonautic partsKinematics equationsSpace vehicle control
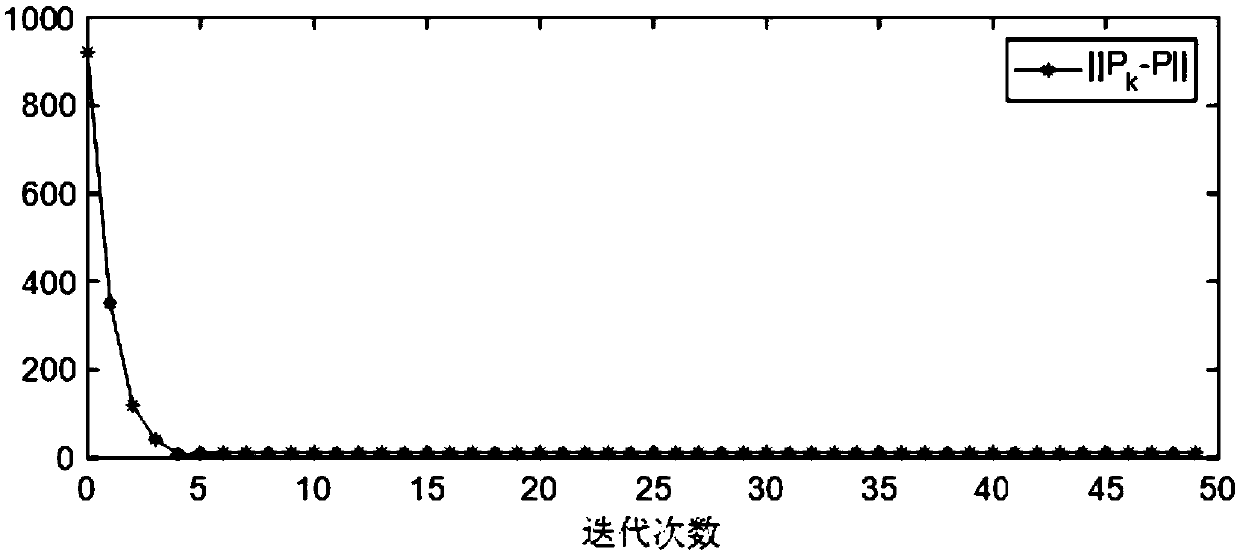
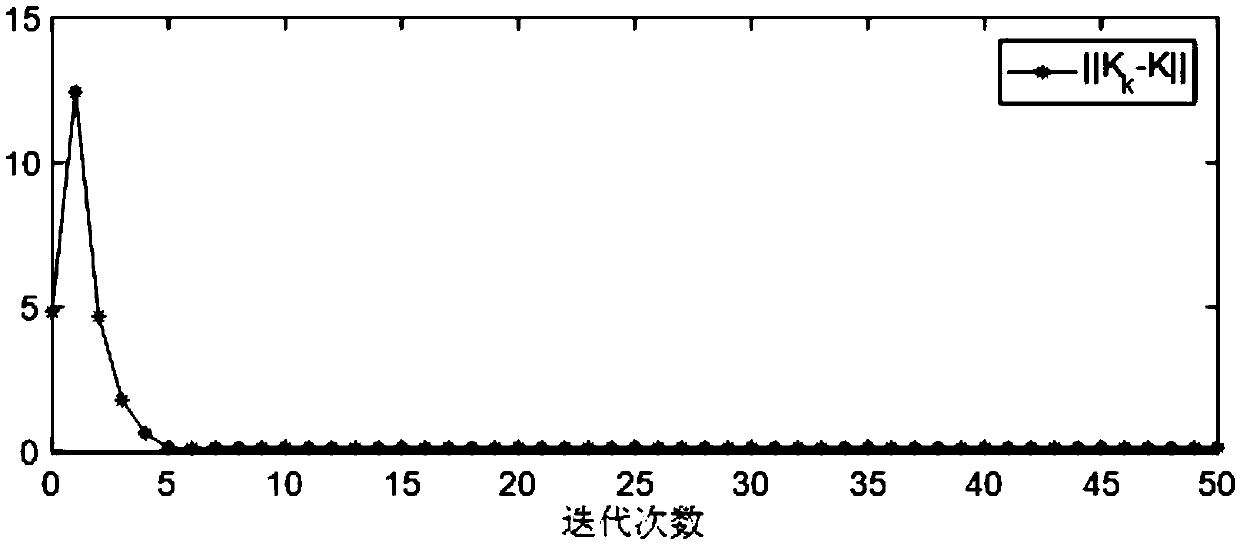
The invention relates to a design method for a data-driven posture controller of a non-cooperative target assembled spacecraft. The invention solves the problem that the design process of the spacecraft is complex due to the fact that the parameter of the assembled spacecraft is unknown when the non-cooperative target assembled spacecraft posture stabilization controller is designed. The method provided by the invention comprises the steps of 1, building a posture kinematical equation and a posture kinetic equation for controlling the posture of the non-cooperative target assembled spacecraft;2, acquiring a linear posture equation according to the step 1, wherein the system matrix parameter is unknown; 3, adopting a parameter Lyapunov equation to design an initial feedback gain K0 of a Kleinman iteration algorithm according to the acquired linear posture equation; and 4, adopting a data-driving method for designing the posture controller of the non-cooperative target assembled spacecraft according to the designed initial feedback gain K0. The method provided by the invention is applied to the field of spacecraft control.
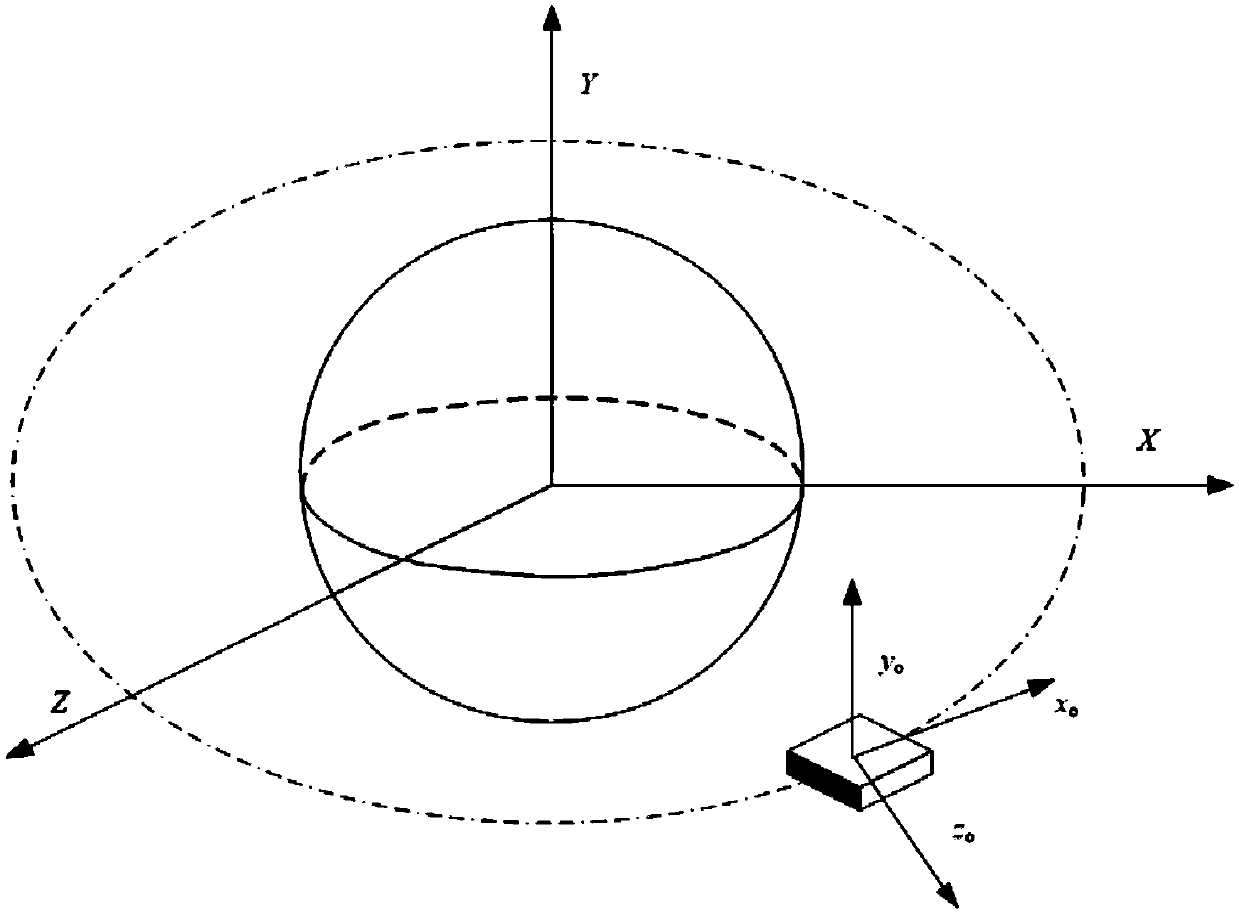
Owner:HARBIN INST OF TECH
Finite time fault-tolerant control method used for remote operation system
ActiveCN110000788AGuaranteed uptimeFast convergenceProgramme-controlled manipulatorSystem impactRobot position
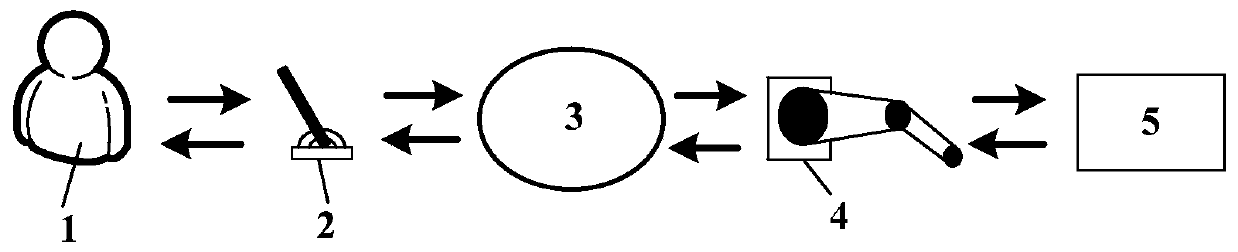
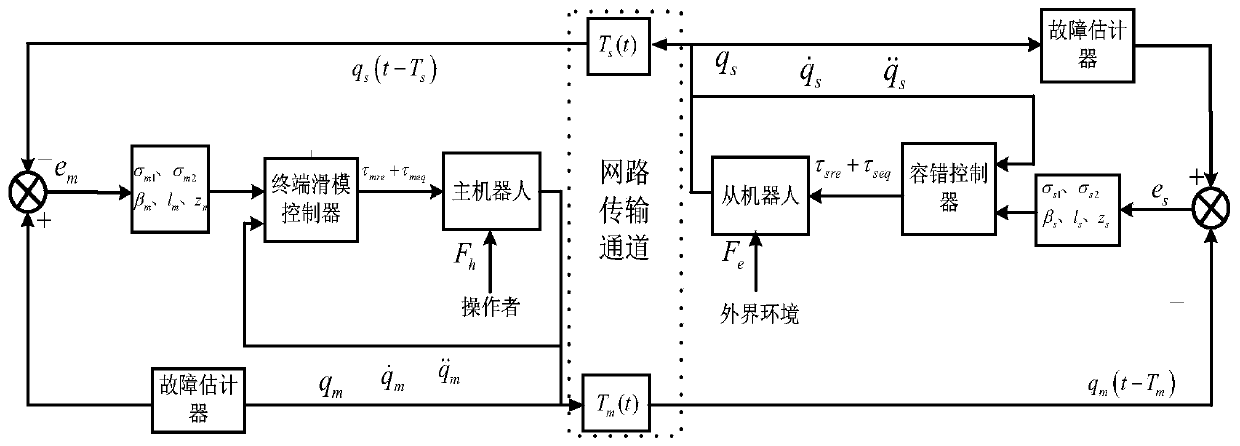
The invention discloses a finite time fault-tolerant control method used for a remote operation system. The method specifically comprises the steps that for the remote operation system with an executor failure, according to measured parameters of main and slave robots, a nominal system is obtained; on the basis of position and speed information of the main and slave robots in the nominal system, finite time is designed for the main and slave robots, and executor failures of the main and slave robots and system uncertain information are estimated in an online manner; on the basis of the measured joint position and speed information, a terminal sliding mode surface is designed; on the basis of the terminal sliding mode surface, the executor failure and the system uncertain estimation information, the finite time control strategy is designed; and the Lyapunov equation is used for building the system convergence rate and controller parameter relation. Through executor failure and system uncertain finite time online precise estimation, the compensation of the executor failure and the system uncertainty for the system influence can be successfully achieved, and the stable running of theclosed-loop remote operation system is ensured.
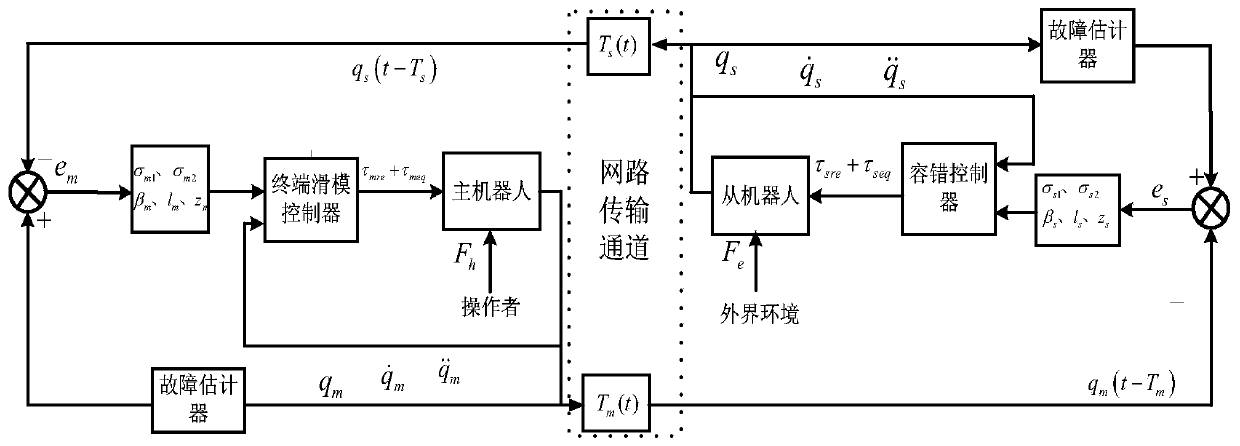
Owner:YANSHAN UNIV
Time-varying feedback finite time control method for controlling limited satellite formation flight system
ActiveCN112286058AGuaranteed escort missionArtificial satellitesSpacecraft guiding apparatusSolution of equationsOrbit (dynamics)
A time-varying feedback finite time control method for controlling a limited satellite formation flight system comprises the steps: step 1, establishing an orbital dynamics model for controlling the limited satellite formation flight system and obtaining a state-space equation, establishing a to-be-tracked signal model and obtaining the state-space equation; step 2, establishing a parameter Lyapunov equation and analyzing the property of the parameter Lyapunov equation, designing an explicit linear time-varying feedback control law through a positive definite solution of the parameter Lyapunovequation, establishing an output adjustment equation, and designing an explicit linear time-varying feedforward control law through a solution of the output adjustment equation; and designing a time-varying state controller for controlling the limited satellite formation flight system through a linear time-varying feedback control law and a linear time-varying feedforward control law; and step 3,constructing an explicit Lyapunov function, and designing controller parameters by utilizing the properties of a parameter Lyapunov equation and an adjustment equation solution to ensure that the accompanying satellite completes a tracking task within finite time. The invention aims to realize finite time control of the satellite formation flight system under the condition of limited control.
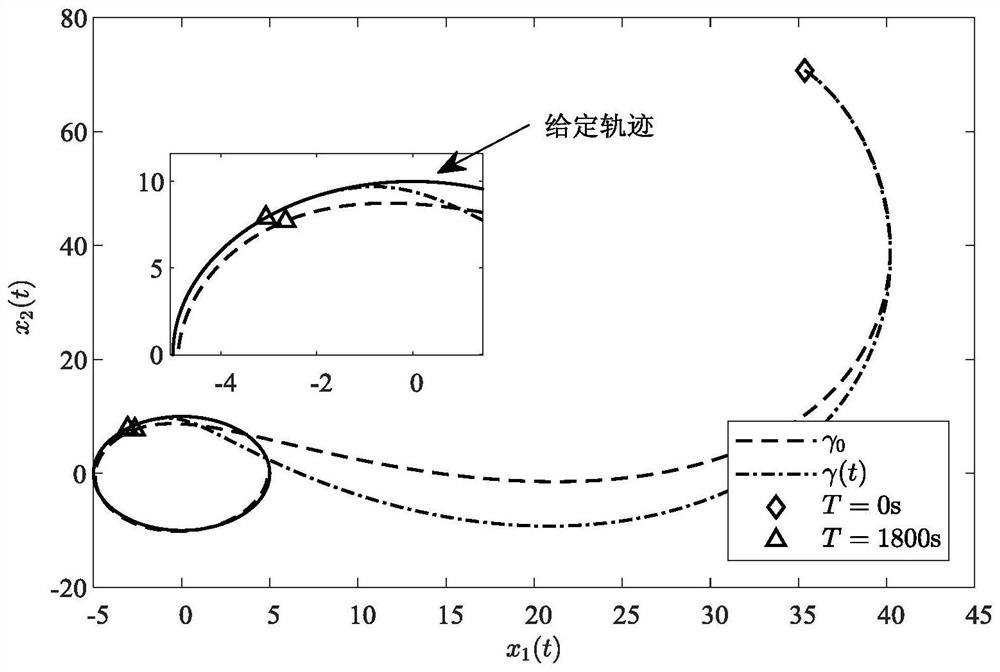
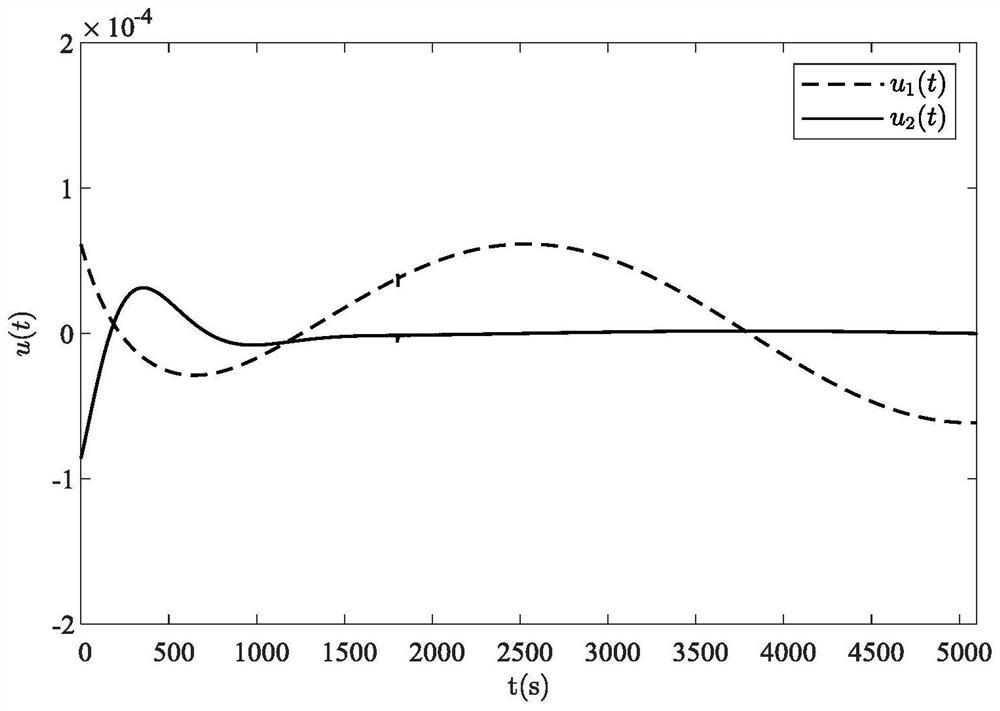
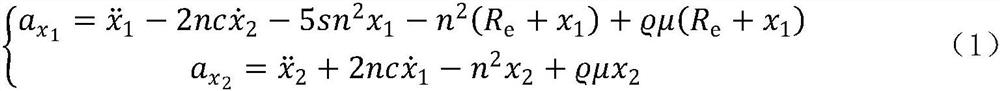
Owner:HARBIN INST OF TECH
Consistency control method for distributed dynamic event-triggered multi-agent system
ActiveCN114296342AEliminate the effects ofEasy to adjust control performanceTotal factory controlAdaptive controlConsistency controlEvent triggered
The invention provides a consistency control method for a distributed dynamic event triggered multi-agent system, and belongs to the technical field of multi-agent system control. According to the method, a novel distributed dynamic event triggering mechanism based on the parameter Lyapunov equation is designed by utilizing the parameter Lyapunov equation, the influence of a feedback gain matrix K and a matrix B on the triggering time interval in the system can be eliminated, and meanwhile, an expression of the minimum triggering time interval is established; the minimum triggering time interval and the unique parameter gamma of the parameter Lyapunov equation have a clear and simple relationship, and the triggering time interval of the system can be dynamically adjusted by adjusting the unique parameter in the parameter Lyapunov equation, so that the balance between the control performance of the system and the triggering time interval is realized, and the stability of the system is improved. While the multi-agent system achieves the state consistency, the communication load and the mechanical loss of the actuator are effectively reduced, and the engineering realization is easy.


Owner:UNIV OF ELECTRONICS SCI & TECH OF CHINA
Adaptive fast speed tracking control method for uncertain underwater robot
ActiveCN110908389AEliminates the need to obtain informationKinetic equation simplificationAltitude or depth controlControl objectiveDesign control
An adaptive fast speed tracking control method for an uncertain underwater robot comprises the following steps of designing a control target for an underwater robot kinematics model according to the actual application of a robot; estimating an uncertain part of a system model and the unknown external interference online by using a time delay estimation technology, and further designing an integralterminal sliding mode surface; designing an adaptive controller based on the integral terminal sliding mode surface and an underwater robot kinematics model, and defining a gain variable in a controllaw; utilizing a Lyapunov equation to prove the stability of the system, and verifying the rationality of the designed integral terminal sliding mode surface and the self-adaptive controller. According to the present invention, the problem that an existing controller depends on the underwater robot model information, is solved, namely the designed controller is independent of the system model, sothat the influence of the model uncertainty and the unknown interference on an underwater robot system is overcome, the robust performance of the system is improved, the controller design is simplified, and the method is conducive to being applied to the engineering practice.
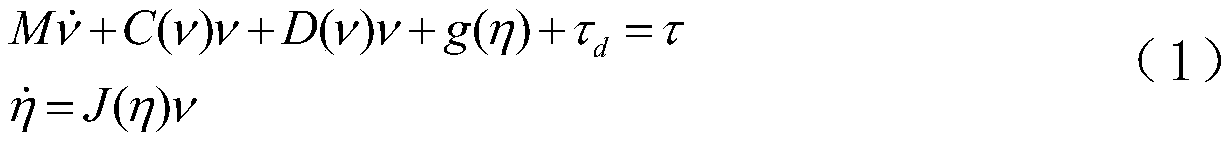
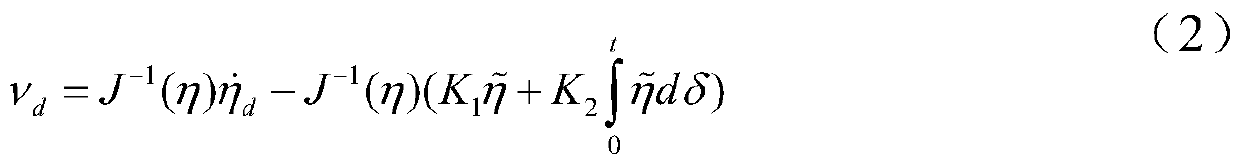
Owner:YANSHAN UNIV
C-RAN system resource allocation method for balancing long-term energy efficiency and network stability
ActiveCN111107645AImprove performanceHigh level techniquesWireless communicationQuality of serviceResource assignment
The invention provides a C-RAN system resource allocation method for balancing long-term energy efficiency and network stability. The method comprises the following steps: establishing a hybrid energysupply C-RAN mathematical model in combination with energy cooperation; establishing an objective function and constraint conditions of a long-term energy efficiency optimization problem; convertinga system long-term energy efficiency optimization problem into a single time slot optimization problem based on the thought of a Lyapunov equation and a penalty function; and solving the converted single time slot optimization problem by adopting a joint resource allocation optimization algorithm. According to the method, system resources (transmission power, cooperative energy and power grid energy supply) can be optimally allocated, the balance between the long-term energy efficiency of the system and the network stability is effectively improved. The system performance is optimized, so thatthe hybrid energy supply C-RAN system adopting energy cooperation meets various long-term and instantaneous service quality requirements, and the method has a wide application prospect.


Owner:SOUTHEAST UNIV
Robot control method, computing device and storage medium
ActiveCN111230870AAchieving Adaptive Impedance ControlGuaranteed stabilityProgramme-controlled manipulatorDynamic modelsSimulation
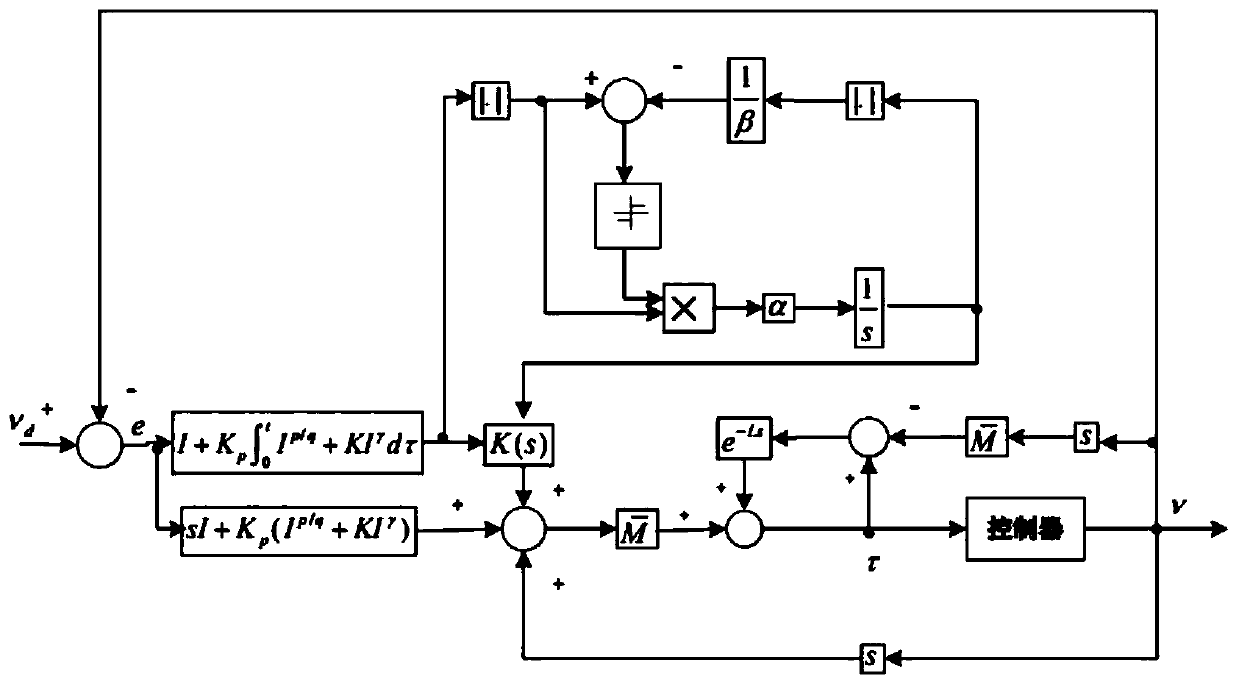
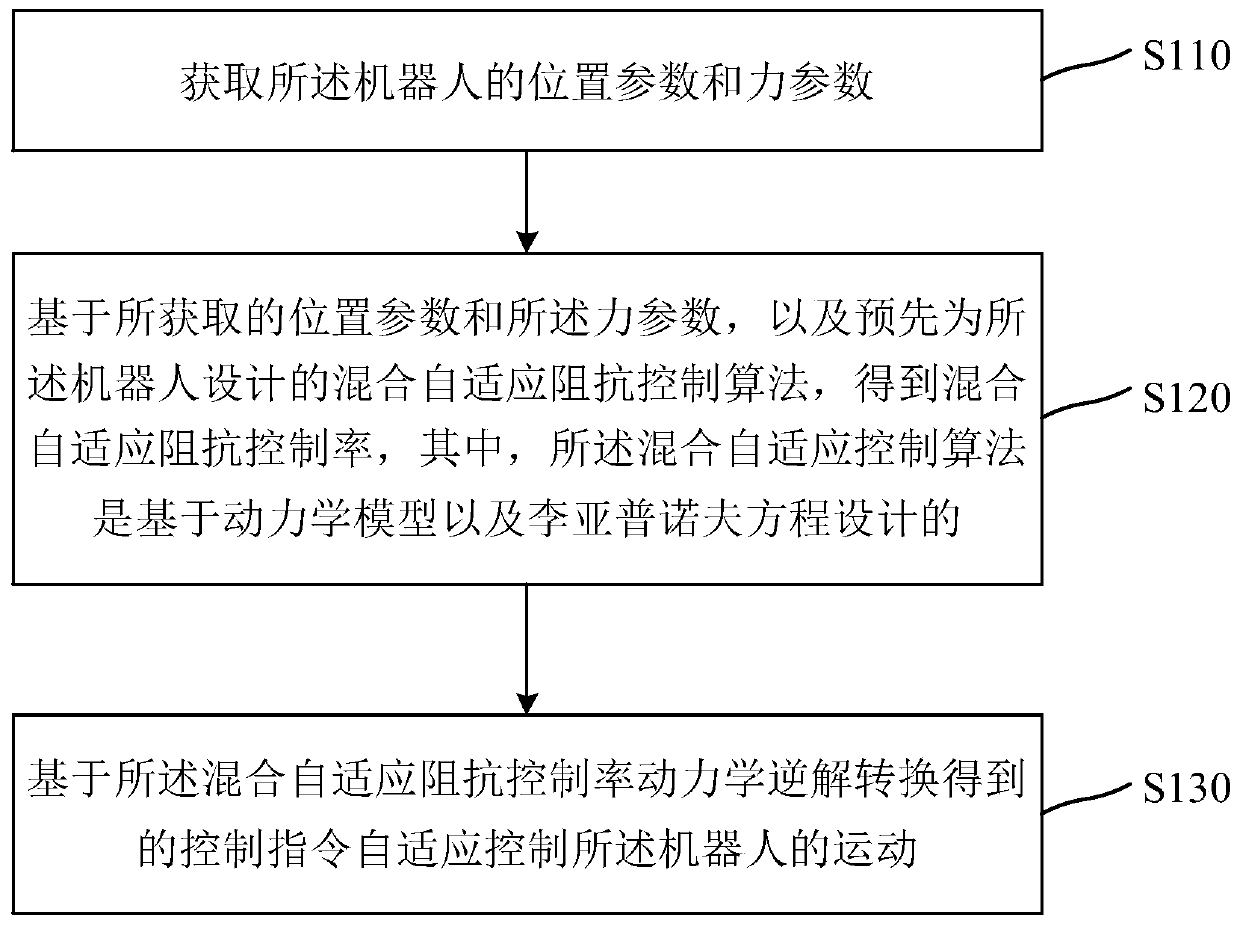
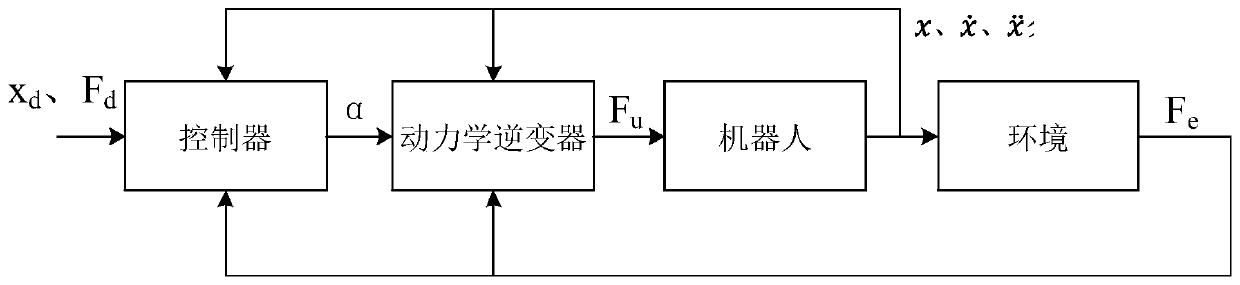
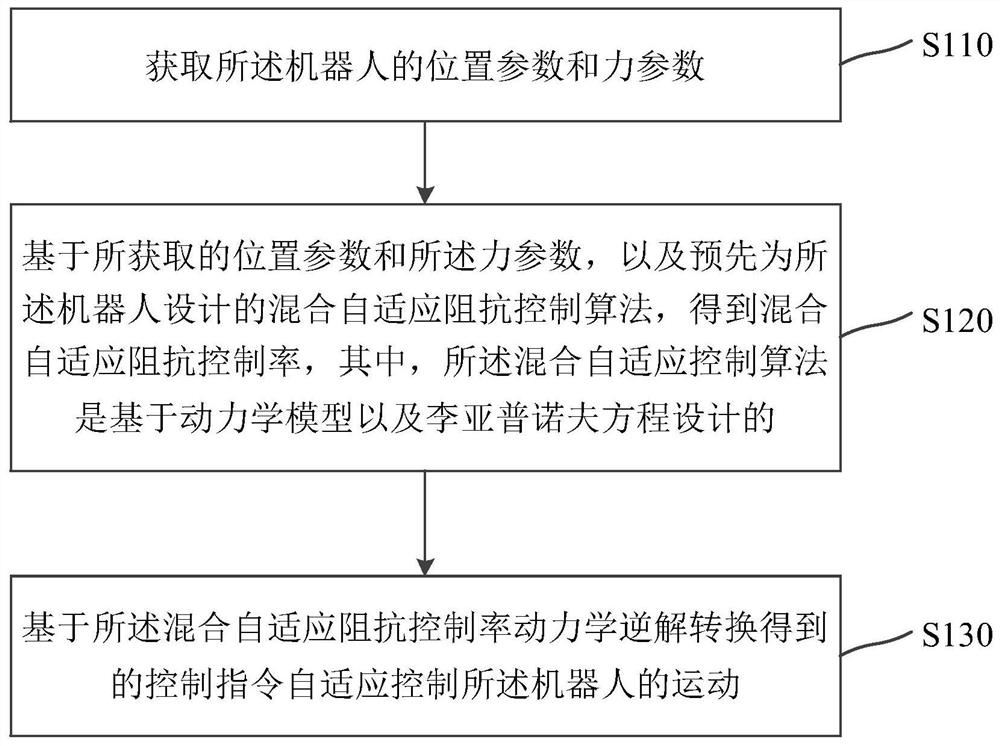
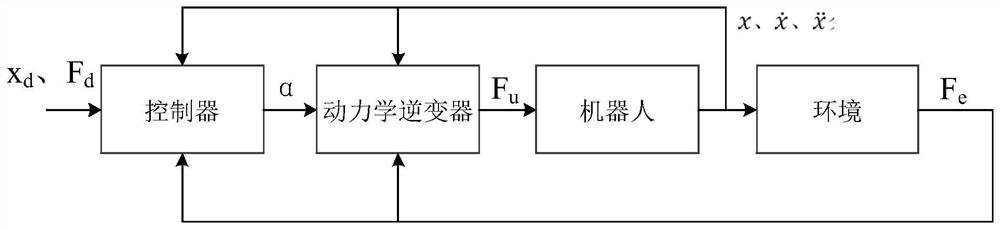
The invention discloses a robot control method, a computing device and a storage medium. The method includes the steps that position and force parameters of a robot are acquired; based on the acquiredposition and force parameters and a hybrid adaptive impedance control algorithm designed for the robot in advance, hybrid adaptive impedance control rates are obtained, wherein the hybrid adaptive impedance control algorithm is designed based on a dynamic model and a Lyapunov equation, and the hybrid adaptive impedance control rates include the inner loop adaptive impedance control rate corresponding to a position control subspace of the robot and the outer loop adaptive impedance control rate corresponding to a force control subspace of the robot; and the motion of the robot is adaptively controlled based on a control instruction obtained by dynamic inverse solution conversion of the hybrid adaptive impedance control rates. Thus, a hybrid adaptive impedance control strategy is designed in combination with a Lyapunov method so as to provide support for ensuring the stability and effectiveness of impedance control and achieving compliant, safe and reliable human-machine interaction.
Owner:SHANGHAI ELECTRICGROUP CORP
Maximum power tracking fuzzy control method of uncertain wind driven generator system
ActiveCN112486019AEffective controlImprove control performanceWind energy generationAdaptive controlWind drivenLoop control
The invention belongs to the field of variable-speed wind power generation control, and provides a maximum power tracking fuzzy control method of an uncertain wind generating set. The method comprisesthe following steps of: acquiring stator voltage and current of a wind driven generator, and constructing a wind driven generator model with uncertainty, disturbance and noise interference by combining related parameters of the wind driven generator; according to a T-S fuzzy linearization rule, carrying out linearization processing on the wind driven generator model, and then carrying out infinite norm closed-loop control maximum power tracking; based on a model with an interference estimation system, comprehensively considering the maximum power tracking error and the interference error, andsolving related control parameters by constructing a Lyapunov equation so as to perform maximum power tracking fuzzy control on the wind generating set.


Owner:JIUJIANG UNIVERSITY
Method for designing discrete gain scheduling controller of multi-balance-point saturation switching system and method for controlling BTT guided missile
The invention discloses a method for designing a discrete gain scheduling controller of a multi-balance-point saturation switching system, and relates to a method for designing a gain scheduling controller in the control field. The invention further relates to a method for controlling a BTT guided missile. The method aims at solving the problem that balance points, obtained through conversion of a design signal tracking controller, of subsystems of a practical system are not all the same. According to the method, the multi-balance-point linear switching system is built with the parameter Lyapunov equation method and the ellipsoid invariant set theory according to state vectors of the selected system, and the discrete gain scheduling controller of the multi-balance-point saturation linear switching system under a switch path related to time is designed. The method is suitable for designing the discrete gain scheduling controller of the multi-balance-point saturation switching system.


Owner:HARBIN INST OF TECH
All-state control method for flexible master-slave robot system under time-varying delay
ActiveCN111136633AAchieving global asymptotic stabilityRealize precise location trackingProgramme controlProgramme-controlled manipulatorRobotic systemsBackstepping
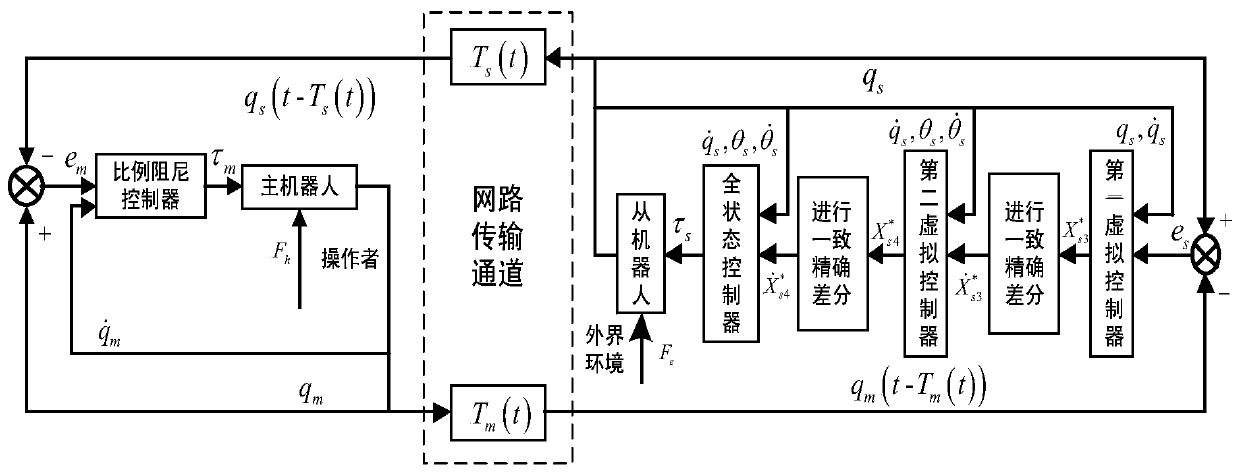
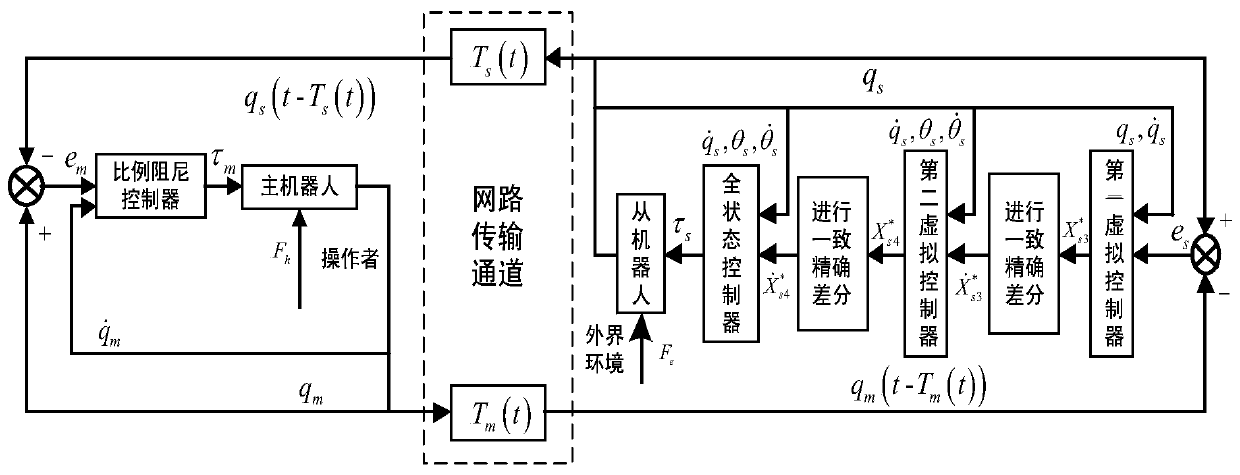
The invention discloses an all-state control method for a flexible master-slave robot system under time-varying delay. The method comprises the following steps of designing a proportional damping controller based on position error and speed and an all-state feedback controller based on a backstepping technique separately for the master robot and the slave robot in a remote operating system composed of a master robot and a slave robot through a network; designing a high-dimension consistent precise differentiator to achieve precise differentiation of a virtual controller; and constructing a Lyapunov equation, establishing a system time-lag related stability criterion, and providing a controller parameter selection standard to achieve global stability of the flexible master-slave robot system under time-varying delay. For the flexible master-slave robot system, the all-state feedback controller based on the backstepping technique and the high-dimension consistent precise differentiator is adopted, so that position precise tracking of a control system in a global range is achieved, global asymptotic convergence of the system is guaranteed, and the robustness of the system is improved.
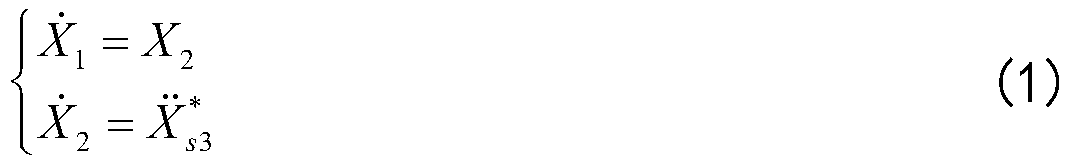
Owner:YANSHAN UNIV
Dynamic beam scheduling and power control method for multi-satellite communication network
The invention discloses a multi-satellite communication network dynamic beam scheduling and power control method, and belongs to the field of resource allocation in satellite communication. The implementation method comprises the following steps: constructing a multi-satellite communication network model, constructing a multi-satellite communication network data queue model based on the network model, and constructing a multi-satellite communication network energy queue model; constructing a queue control model based on a Lyapunov equation; constructing a joint optimization problem of hopping beam scheduling and power control based on a drift and penalty function; reconstructing and approximating the joint optimization problem of the hopping beam scheduling and the power control by using an SCA algorithm; decomposing an approximated joint optimization problem by adopting a Benders decomposition framework, wherein the joint optimization problem is divided into a power control sub-problem and a beam scheduling main problem; solving the power control sub-problem and the beam scheduling main problem to obtain an optimal solution; and iterative optimization is carried out, and dynamic beam scheduling and power control of the multi-satellite communication network are realized according to the optimal solution, so that a multi-satellite network dynamic system reaches long-term stability, and user fairness is realized on flow distribution.

Owner:BEIJING INST OF TECH
Data-driven attitude controller design method for non-cooperative target assembly spacecraft
ActiveCN108804846BStable Linear Globally Stabilized Approximate Optimal ControllerStable Linear Global StabilizationCosmonautic vehiclesCosmonautic partsKinematics equationsSpacecraft attitude control
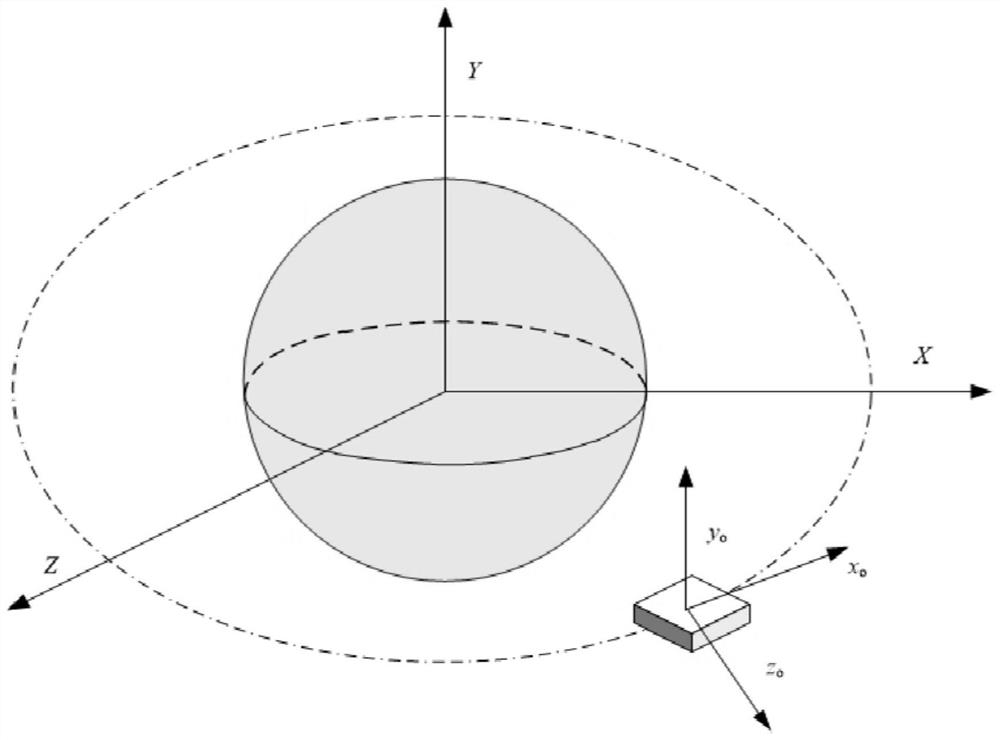
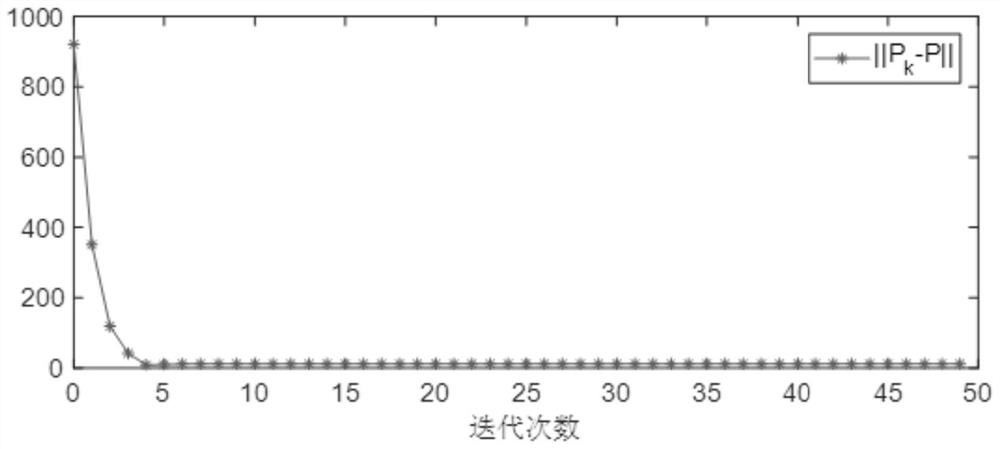
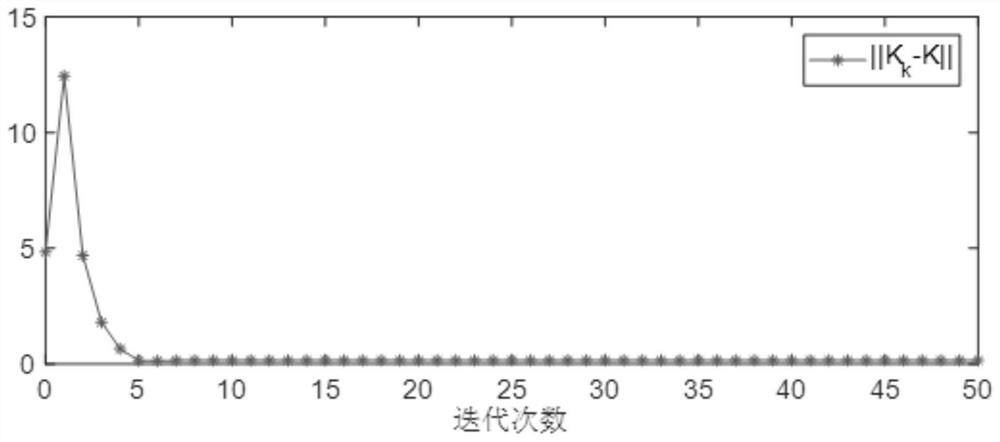
A data-driven attitude controller design method for a non-cooperative target assembly spacecraft, the invention relates to a data-driven attitude controller design method for a non-cooperative target assembly spacecraft. The invention aims to solve the problem that the spacecraft design process is complicated because the parameters of the combined spacecraft are unknown when designing the attitude stability controller of the non-cooperative target combined spacecraft. The present invention includes: 1: establishing the attitude kinematics equation and attitude dynamics equation of the non-cooperative target assembly spacecraft attitude control; 2: obtaining the linearized attitude equation according to step 1, wherein the system matrix parameters are unknown; 3: according to the obtained linear The initial feedback gain K of the Kleinman iterative algorithm is designed by using the parametric Lyapunov equation to optimize the attitude equation 0 ; Four: According to the design of the initial feedback gain K 0 Using a data-driven approach, an attitude controller for a non-cooperative target assembly spacecraft is designed. The invention is used in the field of spacecraft control.
Owner:HARBIN INST OF TECH
Fixed time control method for teleoperated robot based on fast terminal sliding mode
ActiveCN105319972BFast convergenceImprove anti-interference abilityAdaptive controlRobotic systemsOperational system
The invention relates to the technical field of remote operating robot synchronous control, specifically discloses a remote operating robot fixed time control method based on a rapid terminal sliding mode. The method includes: selecting a master robot and a slave robot to form a remote operating system, measuring system parameters of the master robot and the slave robot respectively, measuring position information of the master robot and the slave robot on line, obtaining speed information of the master robot and the slave robot, designing a rapid terminal sliding mode surface, based on the designed rapid terminal sliding mode surface, using the system parameters of the main robot and the slave robot to design a self-adaptive fixed time controller, and using a Lyapunov equation to provide a relational expression between a parameter self-adaptive law, controller parameters, sliding mode surface parameters and system convergence time, thereby determining the controller parameters and the sliding mode surface parameters according to requirements of practical application for system convergence time and a relational expression between the system parameters and the system convergence time. The remote operating robot fixed time control method based on the rapid terminal sliding mode makes up for the defects in control speed and control accuracy of an existing remote operating robot system control method.


Owner:YANSHAN UNIV
Robot control method, computing device and storage medium
ActiveCN111230870BAchieving Adaptive Impedance ControlGuaranteed stabilityProgramme-controlled manipulatorDynamic modelsSimulation
The application discloses a robot control method, a computing device and a storage medium. The method includes: obtaining position parameters and force parameters of the robot; based on the obtained position parameters and force parameters and a hybrid adaptive impedance control algorithm designed for the robot in advance, a hybrid adaptive impedance control rate is obtained, wherein the hybrid adaptive control algorithm is designed based on the dynamic model and Lyapunov equation, and the hybrid adaptive impedance control rate includes the inner loop adaptive impedance control rate corresponding to the robot's position control subspace and the outer loop self-adaptive impedance control rate corresponding to the robot's force control subspace. Adaptive impedance control rate; the motion of the robot is adaptively controlled based on the control command obtained by the dynamic inverse conversion of the hybrid adaptive impedance control rate. Therefore, a hybrid adaptive impedance control strategy is designed by combining the Lyapunov method to provide support for ensuring the stability and effectiveness of impedance control and realizing compliant, safe and reliable human-computer interaction.
Owner:SHANGHAI ELECTRICGROUP CORP
Control method and device for aircraft subjected to class gap lag and output constraint
ActiveCN114035594AImprove stabilityHigh precisionSustainable transportationAttitude controlNonlinear modelFlight vehicle
The invention discloses a control method and device for an aircraft subjected to class gap lag and output constraint, and the method comprises the steps of building a nonlinear model of an aircraft system according to the class gap lag output; constructing a controller and an adaptive law of the aircraft system according to the nonlinear model; constructing a Lyapunov equation; verifying the stability of the aircraft system according to the Lyapunov equation; and when the stability meets a preset requirement, simulating the aircraft system to obtain a simulation result. The method is high in precision and stability and can be widely applied to the technical field of aircraft control.


Owner:GUANGZHOU UNIVERSITY
Machine learning driven colorectal cancer kit detection data intelligent processing method
The invention provides a machine learning driven colorectal cancer kit detection data intelligent processing method, and relates to the technical field of data processing, the method comprises the following steps: obtaining multiple groups of healthy sample detection data obtained by a colorectal cancer kit; determining a steady state center representing a health state based on each group of health sample detection data, and establishing a Jacobian matrix describing the health state through a regression fitting process; constructing a Lyapunov equation by taking the Jacobian matrix as input, and solving a positive definite matrix of the Lyapunov equation; establishing a Lyapunov energy function based on the positive definite matrix so as to quantify the detection data into energy cost deviating from a steady-state center; acquiring to-be-detected data of the colorectal cancer kit; inputting the data to be detected into the Lyapunov energy function, and solving the change rate of the Lyapunov energy function; and when the change rate of the Lyapunov energy function is less than zero, outputting that no colorectal cancer risk exists, otherwise, outputting that the colorectal cancer risk exists.

Owner:CANCER HOSPITAL AFFILIATED TO GUANGXI MEDICAL UNIV
Filtering method for uncertain system with complex multiplicative noise and random time delay
The invention relates to the technical field of signal processing, in particular to a filtering method for dealing with a system with complex multiplicative noise and random time delay uncertainty, which designs a reasonable system model of a multi-sensor networked system meeting conditions, and adopts a maximum and minimum robust estimation principle, a de-randomization method and a virtual noise technology. The system is converted into a multi-model multi-sensor system only with uncertain noise variance, an augmented noise method, a non-negative definite matrix factorization method and a Lyapunov equation method are applied, two robust centralized fusion steady-state Kalman estimators are obtained, and the robustness of the estimators is further proved. The method can be used for solving the problem of robust fusion Kalman filtering of multi-sensor single-channel ARMA signals with random parameter matrixes, uncertain noise variance and networked random uncertainty.

Owner:ZHEJIANG GONGSHANG UNIVERSITY
Power system stability optimization method and device based on multi-state variables, terminal equipment and storage medium
PendingCN120638300AContigency dealing ac circuit arrangementsComplex mathematical operationsPerformance functionElectric power system
The invention discloses an electric power system stability optimization method and device based on multiple state variables, terminal equipment and a storage medium, and belongs to the field of electric power systems.The method comprises the steps that a quadratic Lyapunov equation is constructed and projected to a two-dimensional state space plane composed of any two different system state variables, obtaining stability domain boundary curve equations of different system working conditions; calculating a generalized participation factor according to the stability domain boundary curve equation and the initial equilibrium point before disturbance; screening related state variables according to the generalized participation factors; performing time integration on the quadratic Lyapunov equation to determine a system performance function, and solving partial derivative to obtain a generalized damping coefficient; optimizing related state variables according to the generalized damping coefficient; and adjusting system control parameters according to the optimized related state variables. By implementing the method and the device, a high-dimensional problem can be decomposed into a plurality of two-dimensional sub-problems, the analysis complexity is reduced, and the problem that in the prior art, the system complexity only aims at single parameter optimization is solved.

Owner:GUANGDONG POWER GRID CO LTD
Finite Time Fault Tolerant Control Method for Remote Operating System
ActiveCN110000788BGuaranteed uptimeFast convergenceProgramme-controlled manipulatorOperational systemControl engineering


Owner:YANSHAN UNIV
Man-machine sharing control method for exogenous input system under Nash equilibrium
The invention belongs to the technical field of man-machine cooperative control, and particularly relates to a man-machine sharing control method for an exogenous input system under Nash equilibrium, which comprises the following steps of: constructing a man-machine sharing control system model with exogenous input items, and setting a cost function of man-machine parties; a man-machine non-cooperative differential game model is considered, an information structure of man-machine interaction meets a closed-loop perfect state mode, a control target is Nash equilibrium between cost functions of the two parties, and a Nash equilibrium solution form of human and machine control input and an algorithm of control gain and additional items are provided; based on fuzziness and uncertainty of human input, constructing an adaptive observer, and combining a Lyapunov equation to obtain a human input estimation gain and an updating law of an additional item; the real-time Nash equilibrium solution of man-machine sharing control in an exogenous input system is provided while the influence of exogenous input on the system state is restrained, and the method has high scientific significance and application value.

Owner:HARBIN ENG UNIV
A Finite Time Compensation Method for Telecontrol System Interference Based on Terminal Sliding Mode
ActiveCN106647281BLighten the design burdenConvergent precisionAdaptive controlOperational systemDifferentiator
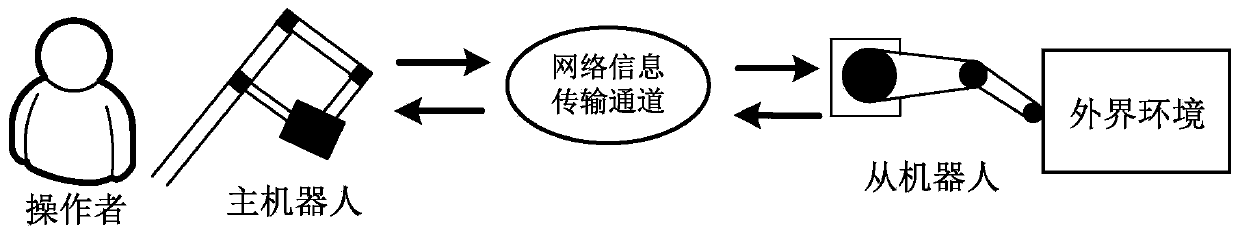
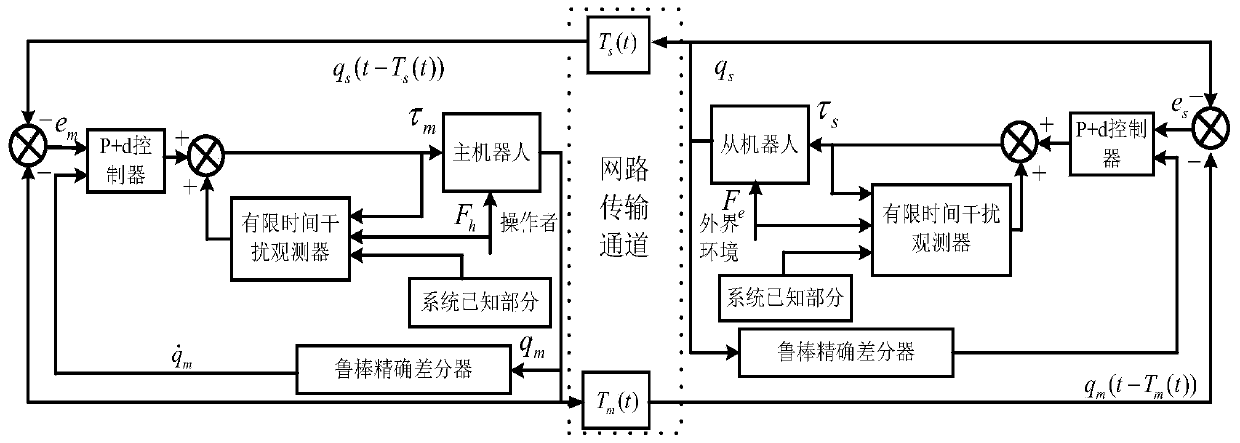
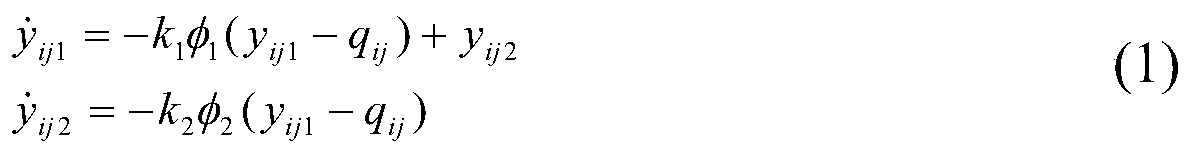
The invention discloses a method for compensating finite interference time of a remote operation system based on a terminal slide model. The method comprises the steps of respectively selecting a master robot and a slave robot so as to form a remote operation system, respectively measuring system parameters of the master robot and the slave robot, measuring power-off position information of the master robot and the slave robot online, obtaining joint speed information of the master robot and the slave robot by virtue of a robust precise differentiator, designing a finite time interference observer based on a terminal slide model, feeding back to the controller design of the master robot and the slave robot, and acquiring a parameter value range of the interference observer by virtue of a Lyapunov equation. By virtue of the method, the problems of low observation speed and limited capacity of an existing observer are solved, the influences caused by parameter indeterminacy and unknown interferences to the remote operation system are overcome, and the anti-jamming performance of the system is improved; and the controller design is simplified, and the application in engineering practice is benefited.
Owner:YANSHAN UNIV