
Patents
Literature
739 results about "Self adjusting" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
A self adjusting force is a force that keeps on adjusting its value in accordance of applied force till it reaches its maximum value named as limiting value .There are 3 forces in nature which are self adjusting. 1.Normal force.
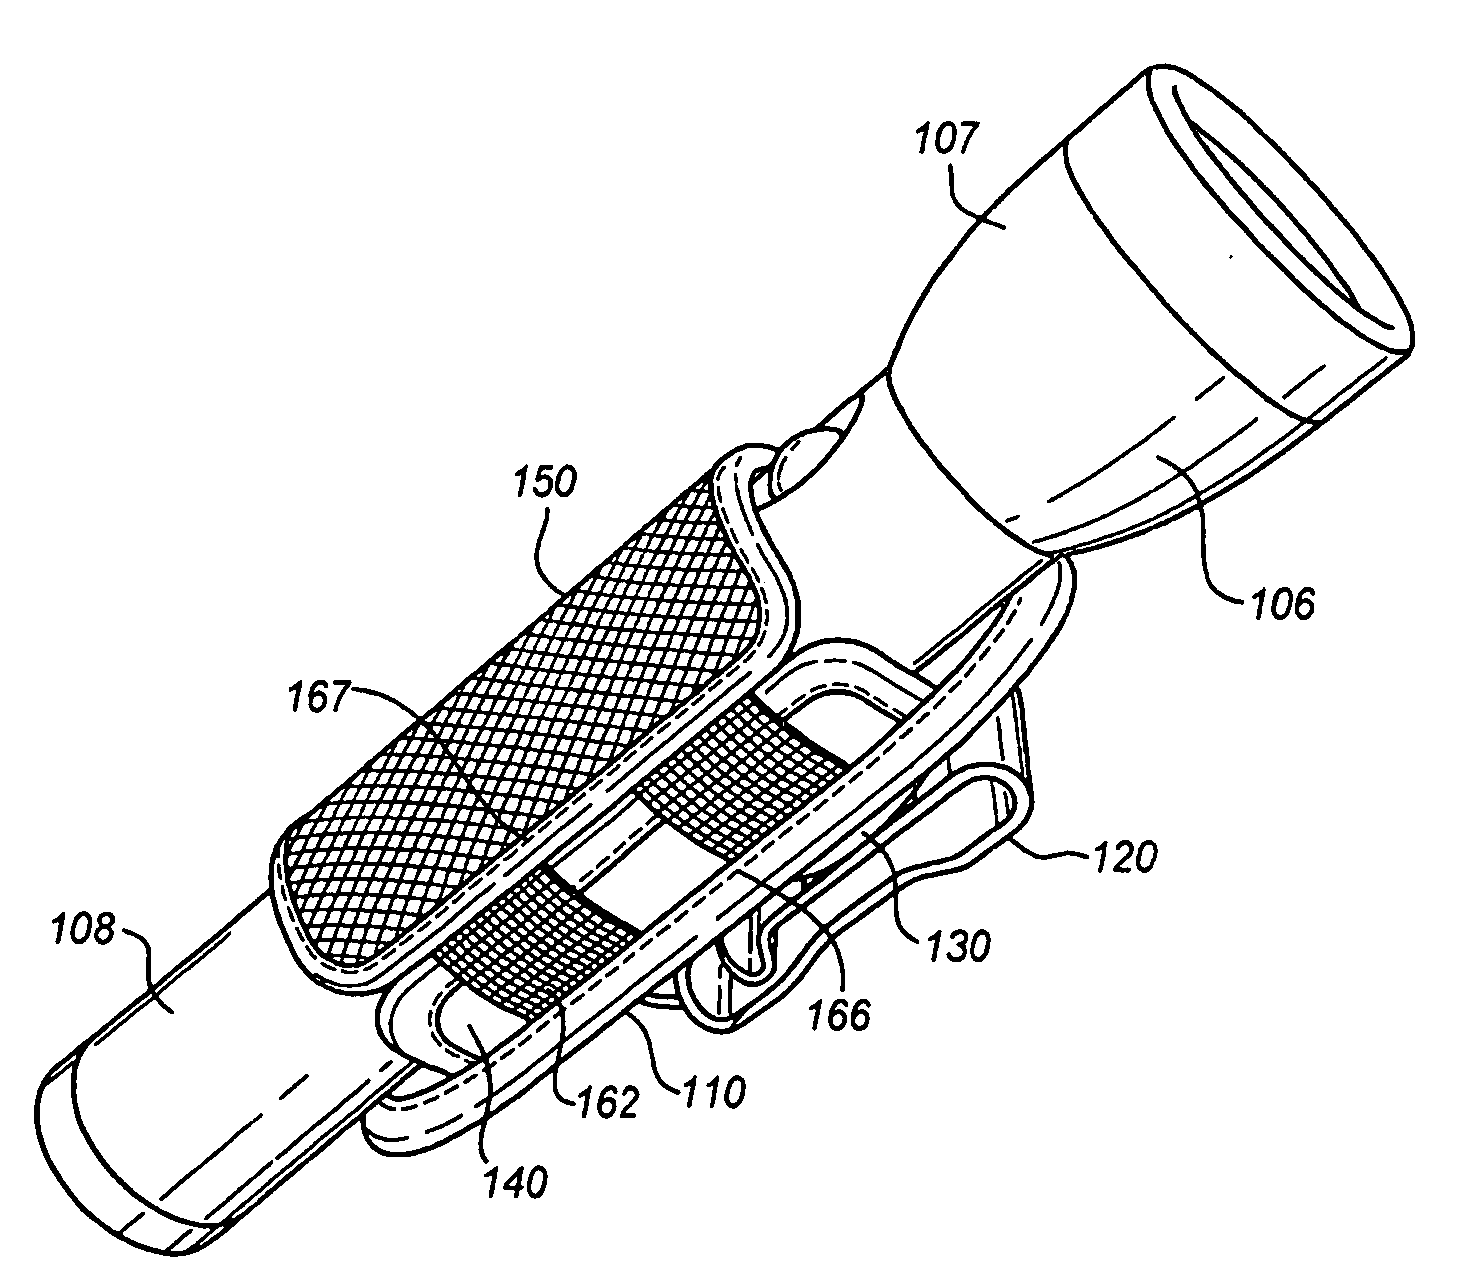
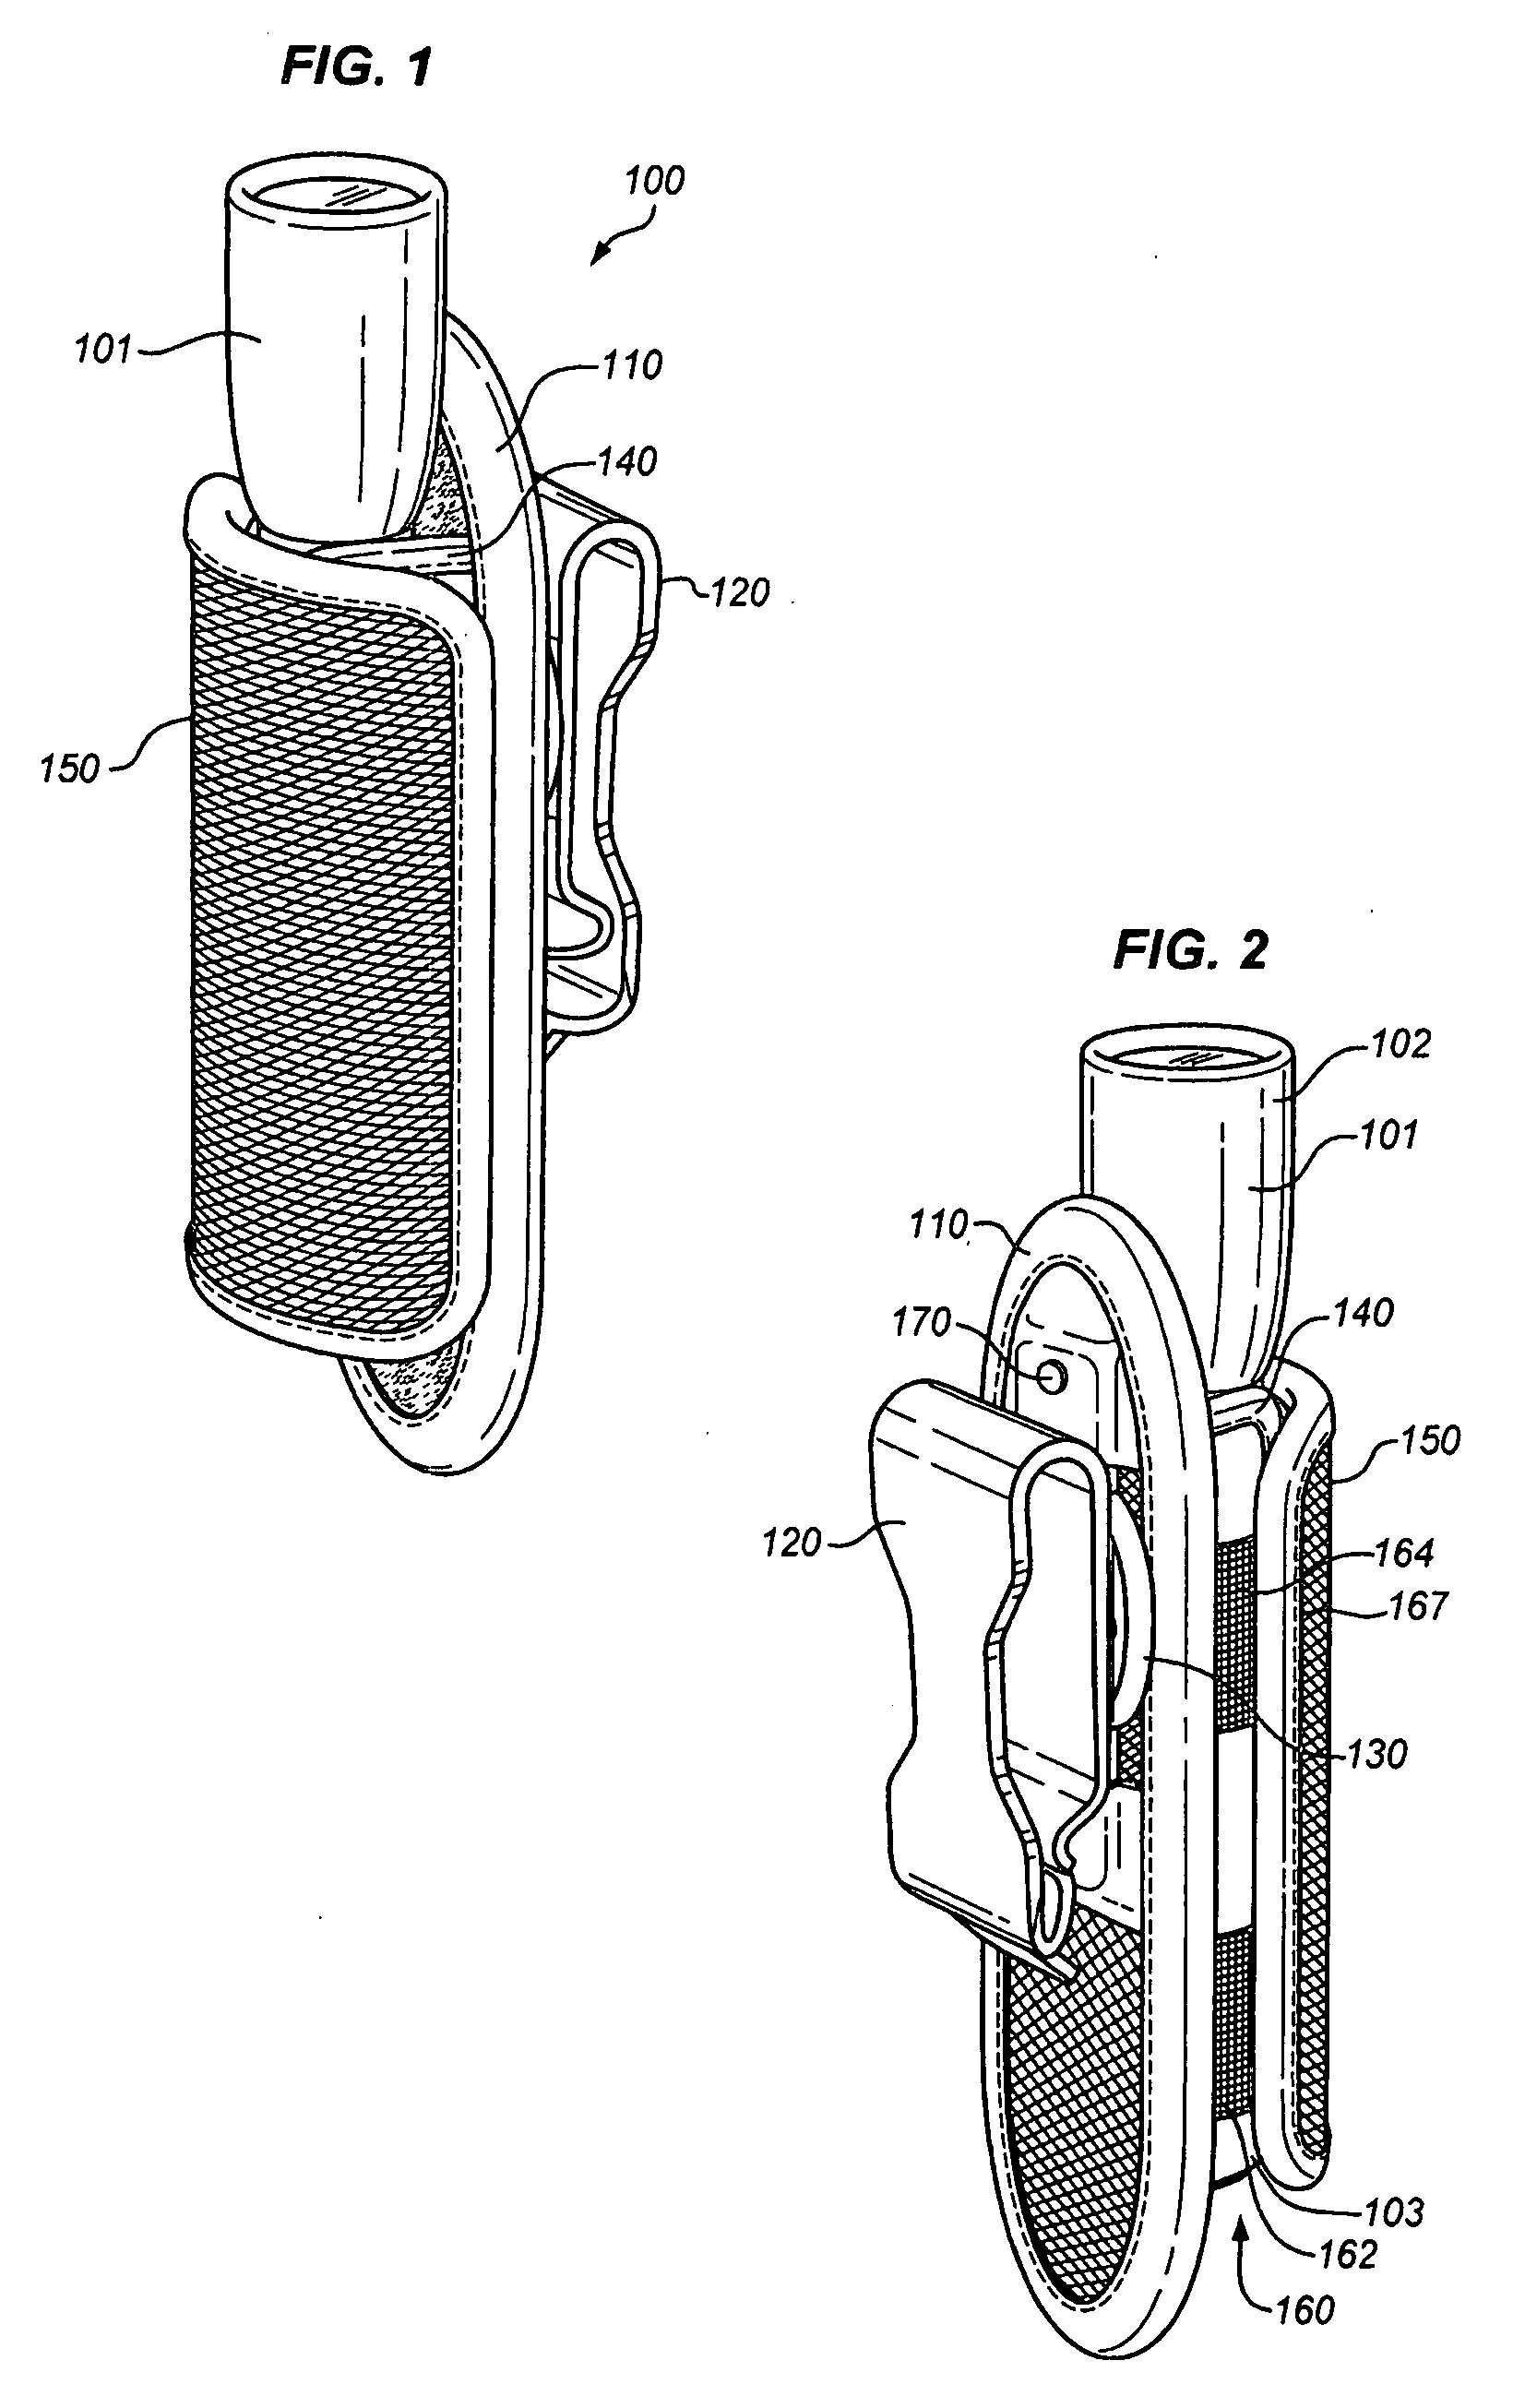
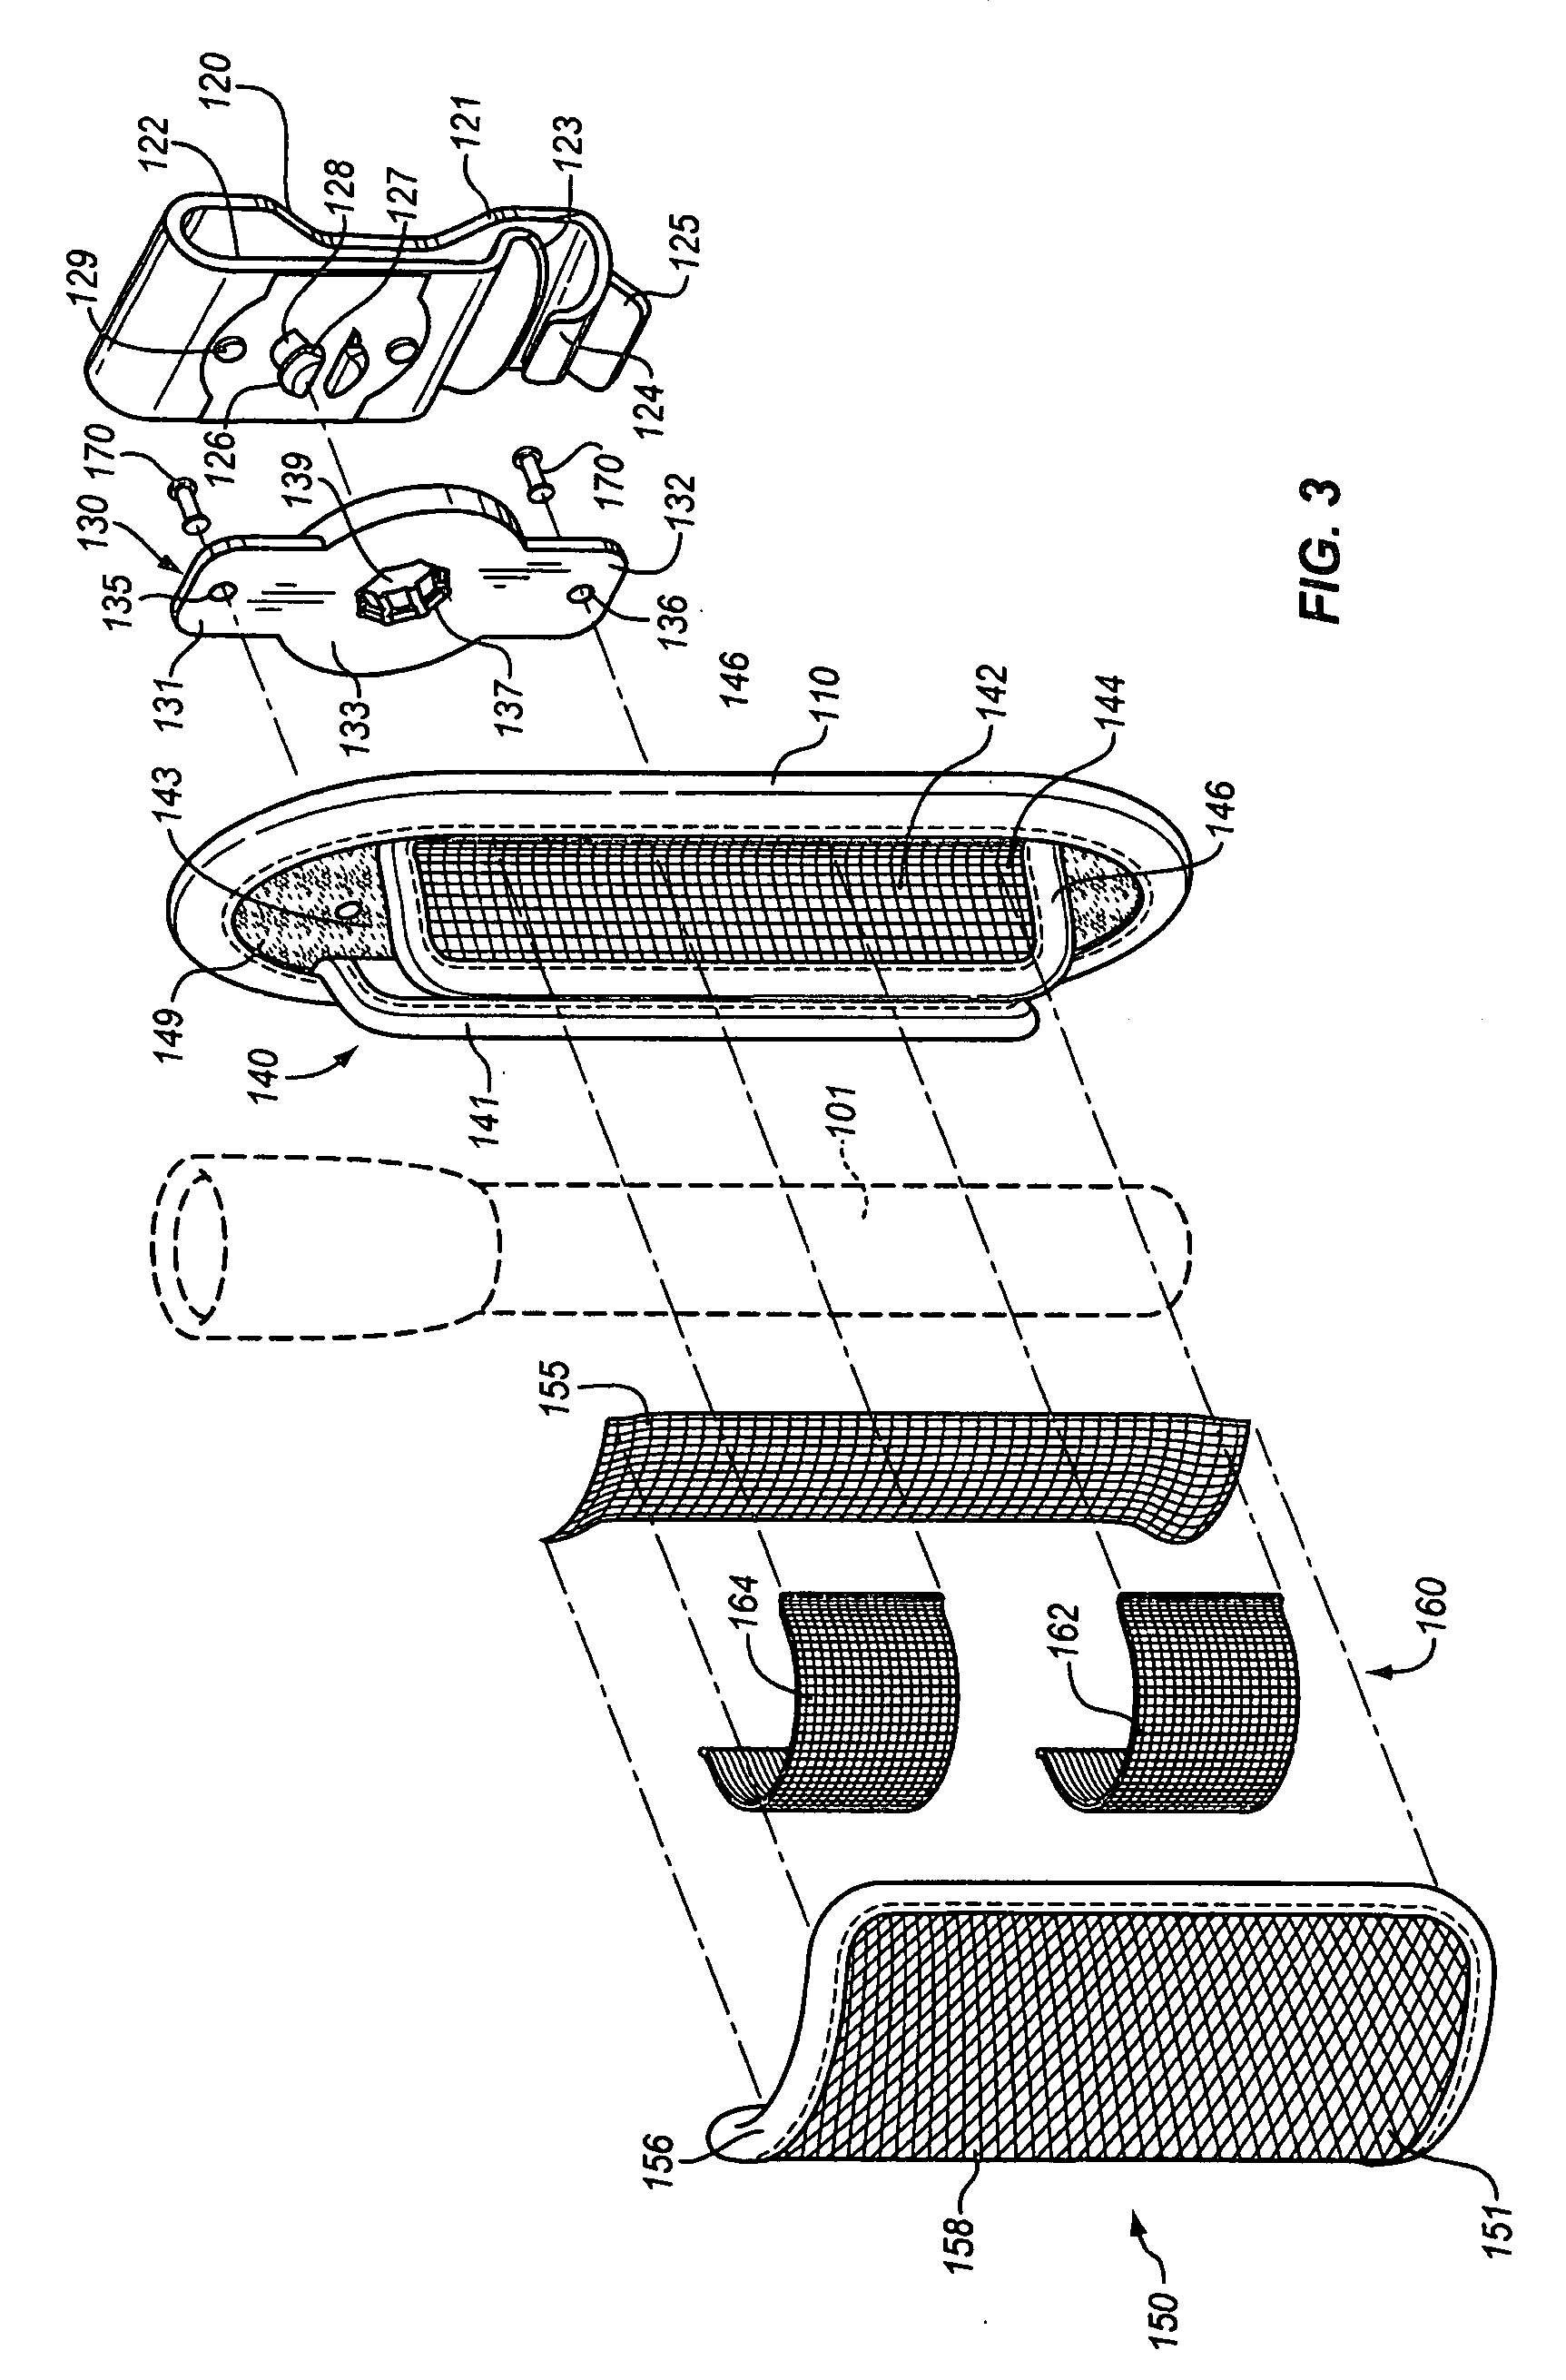
Self-adjusting holster particularly adapted for holding implements of a wide range of sizes
An implement holster comprising a holster support, a first cradle attached to the holster support, a second cradle, and a resilient strap system connected between the holster support and the second cradle, the first cradle fitting within the second cradle. The implement holster further comprises a clip adapted for attaching the holster to a support, a rotator connected between the clip and the holster, and a detent system permitting the holster to be held in a plurality of different positions with respect to the clip.
Owner:NITE IZE
Distribution box assembling and welding device and assembling and welding method thereof
The invention discloses a distribution box assembling and welding device and an assembling and welding method thereof, and relates to the technical field of distribution box assembling. The distribution box assembling and welding device comprises a center shaft, two sets of welding guns symmetrically arranged on a machine shell relative to the center shaft in the axial direction, a moving assembly arranged in the machine shell and used for driving the two sets of welding guns to move synchronously and reversely, and angle adjusting assemblies arranged on the moving paths of the welding guns. The angle adjusting assembly enables the angle of the welding gun to be changed with movement of the welding gun as power, and the angle adjusting assembly can enable the welding gun to be opened by the needed angle. The center shaft serves as a welding zero point, the two sets of welding guns are driven to move towards the opposite welding seams of the distribution box and get close to the opposite welding seams of the distribution box in a reverse movement and welding angle self-adjusting mode, double welding work of the welding seams of the distribution box is achieved, the welding running path is shorter, synchronous welding work can be conducted on the two sets of welding seams of the distribution box at a time, the welding efficiency is improved, and meanwhile the welding efficiency is improved. And the welding quality can be greatly improved, and the welding accuracy is ensured.

Owner:BEIJING HEROSAIL POWER SCI & TECH
Aluminum material shearing machine pressure self-adjusting feeding system based on synchronous rollers
The invention provides an aluminum material shearing machine pressure self-adjusting feeding system based on synchronous rollers, relates to the technical field of aluminum material shearing machines, and adopts three synchronous rollers to be mounted in a mounting groove in the surface of a turntable through a movable block, a pneumatic telescopic rod and a pressure sensor in a combined manner to form multi-point support and tension control on an aluminum material. The console collects an extrusion force signal output by the pressure sensor in real time, calculates an actual pressure value in the horizontal direction through a pressure decomposition algorithm in combination with a turntable angle output by the angle sensor, compares the actual pressure value with a preset tension threshold value to generate an error signal, and drives the pneumatic telescopic rod to dynamically adjust the position of the synchronous roller; and when the error exceeds a set range, the servo motor can be controlled to adjust the angle of the turntable, and the wrapping angle of the synchronous roller is changed to realize tension compensation. The conveying tension of the aluminum material under the complex working condition is kept stable, the conditions of loosening, wrinkling, deviation and too tight snapping are avoided, and therefore the stability of the aluminum material in the conveying process and the follow-up shearing precision are improved.

Owner:HUBEI KING PLASTIC COMPOSITE MATERIAL CO LTD
Flexible arm space robot torque double-domain constraint control method based on improved FWN
The invention discloses an improved FWN-based torque double-domain constraint control method for a flexible arm space robot, and the method comprises the steps: constructing a dynamic model of a flexible arm space robot system, and constructing a torque double-domain constraint control system mathematical model in combination with the posture of a body and the constraint of the amplitude and the amplitude change rate of the control torque of a joint hinge; a torque double-domain constraint controller based on the improved fuzzy wavelet network is constructed, the torque double-domain constraint controller meets a torque double-domain constraint control system mathematical model, and corresponding control laws comprise an improved fuzzy wavelet network control law and an improved fuzzy wavelet network parameter self-adjusting control law; and the body attitude angle and the joint angle of the robot and the deformation coordinate and the vibration amplitude of the flexible arm are adjusted through the control torque which is generated by the torque double-domain constraint controller and subjected to double-domain constraint till the control target is achieved. According to the method, the problems of saturation effect and dynamic performance degradation of the actuator caused by insufficient consideration of double-domain constraints of the torque amplitude and the change rate of the joint driving mechanism are solved.

Owner:厦门工学院
Metal continuous electroplating device with uniform plating layer
The invention discloses a continuous metal electroplating device with uniform plating, which belongs to the technical field of continuous electroplating and comprises a feeding conveying mechanism, a sky rail conveying line, a carrier and a continuous electroplating mechanism. A plurality of lifting conveying modules are fixedly installed at the moving end of the sky rail conveying line, a floating material carrying module is installed on the lower side of each lifting conveying module, and a plurality of hooks used for supporting carriers are evenly and fixedly installed at the bottom of each floating material carrying module at equal intervals. The continuous electroplating mechanism comprises a pre-washing pool, a cleaning pool, a complete electroplating pool, a local electroplating pool and a self-adjusting type shielding module; the base station is fixedly provided with a plurality of pre-washing pools for pre-treating electroplated parts; a pre-washing pool, a cleaning pool, a complete electroplating pool, a cleaning pool, a local electroplating pool and a cleaning pool are sequentially and fixedly mounted on the base table in the moving direction of the sky rail conveying line; and a self-adjusting shielding module is mounted in the local electroplating tank. In this way, continuous electroplating is achieved, and it is ensured that the contact depth of the functional face of the electroplated part and electroplating liquid is consistent.

Owner:SHANGHAI LANFENG AUTO PARTS CO LTD
Wave glider laying and recovery system and collaborative operation method thereof
The invention relates to the technical field of ocean unmanned vehicles, and particularly discloses a wave glider laying and recovery system and a collaborative operation method thereof.The wave glider laying and recovery system is composed of a transferring laying device, a tail buoy, a flat cable recovery device and a salvage recovery rod; the moving, transporting and laying device adopts a modularized quick-release structure and a positive and negative thread screw collinear self-adjusting positioning mechanism and is matched with a hand-pulled spring shackle to achieve five-minute zero-assembly laying, and a tail buoy achieves floating body electric control separation through a waterproof steering engine driving lead screw nut transmission and a guide column-guide sleeve conical self-centering structure. The flat cable recovery device is designed based on an eccentric cam self-locking principle and a progressive clamping mechanism, and is combined with a three-stage hoisting strategy to complete efficient and lossless recovery of the flexible flat cable of 7-8 meters; the invention further discloses a collaborative operation method of the wave glider laying and recovery system, which comprises the processes of moving and positioning, device separation, hand pulling and releasing and underwater unfolding in a laying stage, and a time sequence linkage strategy of buoy separation, positioning and dragging and graded hoisting in a recovery stage.

Owner:CETC NINGBO MARINE ELECTRONICS RES INST
Electric fascia gun self-adaptive to mechanical strength
The invention discloses an electric fascia gun self-adaptive to mechanical strength, and belongs to the technical field of electric fascia guns, the electric fascia gun self-adaptive to mechanical strength comprises a main body mechanism used for relaxing fascia of a patient part or a part needing to be relaxed, and the main body mechanism is provided with a self-adjusting mechanism for adjusting huge strength according to different pressing strength. The self-adjusting mechanism comprises a fixing cylinder fixedly installed in the fascia gun shell. By means of a mechanical self-adjusting mechanism, the pressing force of the hand of a user is directly converted into the impact strength of the operation tail end in real time, when the user presses down forcibly, the displacement of the outer sliding sleeve pushes the sliding column to move outwards without delay through the inclined groove plate and the lifting conical head, the eccentric distance of a transmission system is increased, and the transmission efficiency is improved. The stroke and the impact force of the operation tail end are linearly increased, accurate force feedback can be provided according to different body parts and muscle states, the poor relaxation effect caused by insufficient force is avoided, and damage possibly caused by excessive impact in a sensitive area is also prevented.

Owner:ZHEJIANG RED & BLACK TECH CO LTD
Self-adjusting roller cleaning device for cold rolling mill
The invention relates to the technical field of cold rolling mills, and discloses a self-adjusting roller cleaning device for a cold rolling mill, which comprises a combined cleaning mechanism and an elastic pressure reducing mechanism, the interior of the longitudinal hollow shell is in a hollow state, and the longitudinal hollow shell is installed in the rectangular hollow body. The movable valve plate enables liquid to flow from bottom to top in a one-way mode. The second spiral spring exerts downward elastic pressure on the movable valve plate. According to the self-adjusting roller cleaning device for the cold rolling mill, a cold rolling roller is cleaned in a combined mode of a scraper and a grinding belt, the scraping effect of the scraper can clean some hard sundries, the relative friction of the grinding belt can clean attachments in a wiping mode, and meanwhile, the self-adjusting roller cleaning device for the cold rolling mill is convenient to use. The grinding belt is in bent fit with the cold roller, so that the grinding belt has the characteristic of low pressure intensity per unit area, the effect of effectively cleaning the cold roller can be realized, and the occurrence of a scratching event caused by excessive pressure can be prevented.

Owner:LIAONING PROVINCE SHANYUE MASCH MFG CO LTD
Robotic arm cable assembly method and system
ActiveCN121374654BProgramme-controlled manipulatorLine/current collector detailsPoint cloudRobotic arm
The application discloses a mechanical arm cable assembly method and system, and relates to the technical field of robot vision perception and control, and comprises the following steps: acquiring point cloud data of a working environment; fitting a cable center line according to the point cloud data and determining a relative pose matrix of a cable terminal and a target slot; determining an initial alignment attitude matrix of a mechanical arm end according to the relative pose matrix, so as to obtain initial joint angles of the mechanical arm and use the initial joint angles as a starting point of an assembly action; after selecting a grabbing point on the cable center line and planning an insertion path, entering an insertion stage from the starting point; according to detection of an insertion force and an insertion direction, performing error calculation and compensation until the insertion force change rate and the end pose error meet a set condition, and then determining that the assembly is completed. The application realizes self-perception, self-judgment and self-adjustment flexible assembly, improves assembly precision and robustness, and is suitable for automatic grabbing, guiding and insertion operation of flexible cables in industrial automation production.

Owner:SHANDONG UNIV
Multifunctional water retaining device for water conservancy construction
The invention discloses a multifunctional water retaining device for water conservancy construction, and relates to the technical field of water conservancy projects, the multifunctional water retaining device comprises a base and a first water retaining plate fixed at the top end of the base, a plurality of ground nails are arranged at the bottom end of the base, a self-adjusting assembly and a buffering assembly are arranged in the first water retaining plate, and the buffering assembly is located below the self-adjusting assembly; the self-adjusting assembly comprises an open groove formed in the first water baffle, and a second water baffle is installed in the open groove in a sliding mode. The situation that the height of a traditional water baffle is fixed and cannot be automatically adjusted according to the change of the water level, so that when the water level is higher than the water baffle, the water overflows from the top of the water baffle, and equipment and materials are damaged can be avoided, meanwhile, manual intervention can be reduced, the psychological pressure of constructors can be relieved, the working intensity is reduced, and in an emergency, the construction efficiency is improved. And workers can timely evacuate or take corresponding protection measures, so that the safety can be effectively improved.

Owner:ANHUI & HUAI RIVER WATER RESOURCES RES INST
Intelligent tilting device for a prefabricated, assembled base plate
Intelligent tilting device for a prefabricated, assembled base plate, comprising a base, a tilting support frame and a base plate, characterized in that The tilting support frame comprises a plurality of L-shaped support frames arranged side by side in a row, wherein a first tilting connection seat is provided on a rear side on the underside of a long side of the L-shaped support frame, wherein the first tilting connection seat is connected to the base by means of a pivot shaft, wherein a front side on the underside of the long side of the L-shaped support frame is connected to an end of a push rod, wherein one or more base plate support seats are provided in the middle on a underside of the long side of the L-shaped support frame, wherein the base plate support seat is provided with self-adjusting base plate support seats on both a front and rear side, and wherein an electromechanical sliding block, provided with a snap-lock section, is provided on the top of the short side of the L-shaped support frame.wherein the electromechanical sliding block can move up and down along the short side of the L-shaped support frame, and wherein an electromechanical snap lock is provided in the middle on a left or right side of the long side of the L-shaped support frame, wherein the electromechanical sliding block and the electromechanical snap lock are provided with pressure sensors, wherein the electromechanical sliding block and the electromechanical snap lock clamp the base plate and detect pressure data at a snap point; , The self-adjusting base plate support seat comprises a base plate, a top plate, a steel spring and a spring shaft, wherein an elastic cushion and a distributed pressure sensor are installed at a contact surface position on the top plate, the top plate being connected to the base plate by means of the spring shaft and the steel spring.

Owner:(SUZHOU) RAIL TRANSIT SCI & TECH RES INST CO LTD SHANGHAI CIVIL ENG GRP OF CREC +2
Mechanical arm cable assembly method and system
ActiveCN121374654AProgramme-controlled manipulatorLine/current collector detailsPoint cloudRobotic arm
The invention discloses a mechanical arm cable assembly method and system, and relates to the technical field of robot visual perception and control, and the method comprises the steps: obtaining the point cloud data of a working environment; fitting a cable center line according to the point cloud data and determining a relative pose matrix of the cable terminal and the target slot; an initial alignment attitude matrix of the tail end of the mechanical arm is determined according to the relative pose matrix, and an initial joint angle of the mechanical arm is obtained through solving and serves as a starting point of the assembly action; after a grabbing point is selected on the center line of the cable and a plug-in mounting path is planned, starting to enter a plug-in mounting stage from a starting point; and error calculation and compensation are carried out according to detection of the insertion force and the insertion direction, and it is judged that assembly is completed until the insertion force change rate and the tail end pose error meet set conditions. Self-sensing, self-judging and self-adjusting flexible assembling is achieved, the assembling precision and robustness are improved, and the flexible cable automatic grabbing, guiding and inserting device is suitable for automatic grabbing, guiding and inserting operation of flexible cables in industrial automatic production.

Owner:SHANDONG UNIV
Pressure self-adjusting double-sealing gate valve
The utility model discloses a pressure self-adjusting double-sealing gate valve, and relates to the technical field of gate valves. The pressure relief gate valve comprises a gate valve body, a plugging assembly is arranged in the gate valve body, and a pressure relief assembly is arranged in a plugging disc close to the inlet end of the gate valve body. A second bevel gear drives a first bevel gear to rotate, the first bevel gear drives a threaded rod to rotate, the threaded rod drives a sliding block to reversely move in a sliding groove, the sliding block drives a connecting block to move, and the connecting block drives a plugging disc to move to be attached to a positioning ring, so that the situation that leakage easily occurs due to single sealing can be avoided, and the purpose of improving the sealing performance is achieved; when pressure is applied, the blocking plate moves, water in the pipeline enters the gate valve body from the pressure relief hole, and after the pressure of the pipeline is reduced, the reset spring drives the blocking plate to reset through elastic force to block the pressure relief hole, so that the situation that the gate valve blocking structure is damaged due to too large pressure of the pipeline can be avoided, and the purpose of automatic pressure relief is achieved.

Owner:ZHEJIANG HANWEI VALVE MFG
Gait parameter self-adjusting method based on deep learning
The invention relates to the technical field of intelligent robots, in particular to a gait parameter self-adjusting method based on deep learning. The method comprises the following steps that the initial joint angle of the blind guiding robot is obtained, joint conditioning is carried out, and the joint posture deviation value is determined; attitude calibration is carried out according to the joint attitude deviation value, and attitude calibration parameters are output; starting a radar and carrying out environment perception to generate an environment map; generating point cloud height information based on the environment map; calculating a local slope by using the point cloud height information, and determining a terrain slope value; inputting the terrain slope value into a neural network model, and outputting a foot end trajectory parameter; the blind guiding robot is driven to a preset destination through the foot end track parameters and the posture calibration parameters, and the joint stability is calculated. Based on real-time joint posture calibration and terrain perception of an intelligent robot technology, self-adaptive adjustment of gait parameters of the blind guiding robot is achieved, and gait stability and navigation precision are improved.

Owner:SHANDONG SAIFEITE SAFETY ENG TECH DEV CO LTD
Self-adjusting locking piece for a locking unit
A locking piece includes a housing which has a, in particular, rectangular housing opening and a slide which is arranged in the housing. At the housing side, the slide is guided so as to be able to be linearly displaced between two end positions and which has a locking arm which extends at right-angles with respect to the displacement direction of the slide and protrudes forward through the housing opening. A spring clip is arranged behind the slide, which spring clip extends in the displacement direction and which is anchored at the two clip ends thereof in the housing. The slide is arranged between the housing and the spring clip and is retained in abutment with the housing by the spring clip.

Owner:SPHINX ELEKTRONIK GMBH & CO KG
Gate driver with self-adjusted adaptive dead time
A gate driver circuit includes a high-side region that operates in a first voltage domain; a low-side region that operates in a second voltage domain lower than the first voltage domain; a gate driver configured to drive a power switch between an on-state and an off-state with an adaptive dead time; a capacitor cross-coupled to the high-side region and the low-side region; a logic circuit configured to use the capacitor to detect a voltage transient of the power switch based on a first crossing of a threshold, and detect an end of the voltage transient based on a second crossing of the threshold; and an active-passive discrimination circuit configured to indicate whether the voltage transient is active or passive. The logic circuit is configured to regulate the adaptive dead time based on the second crossing of the threshold and based on the voltage transient being passive.

Owner:INFINEON TECH AUSTRIA AG
Bearing with stable lubricating performance
The invention discloses a bearing with stable lubricating performance, and relates to the technical field of bearing devices, the bearing comprises a static bearing and a dynamic bearing, the static bearing comprises a shell and a porous oil storage bushing, a sealing ring is arranged on one side of the porous oil storage bushing, an oil supplementing mechanism is arranged on one side of the sealing ring, and an auxiliary ring is arranged on one side of the oil supplementing mechanism; a movable bearing is arranged in the porous oil storage bushing and comprises a shearing shaft sleeve, a shaft wheel and supporting frames, the shaft wheel is arranged on the outer wall of the shearing shaft sleeve, the supporting frames are arranged on the two sides of the shearing shaft sleeve, the shearing shaft sleeve and the porous oil storage bushing are combined through the supporting frames, and one side of the shearing shaft sleeve is connected with an oil supplementing mechanism. An oil scraping plate and an oil outlet hole are integrated by rotating an oil supplementing arm, so that dynamic lubrication supply and pore self-cleaning are realized; by adopting the non-Newtonian fluid lubricant, the viscosity is improved under high-speed shearing, and the stability of an oil film under extreme working conditions is enhanced; the connecting block enables the oil supplementing system and the bearing to rotate synchronously, and self-adjusting lubricating circulation is formed.

Owner:GUANGDONG ANANG INTELLIGENT MFG SUPPLY CHAIN TECH CO LTD
Operation load control system and method for corn harvester
The invention relates to the technical field of agricultural machinery load control, in particular to a corn harvester operation load control system and method, and the system comprises a power extraction module, a speed regulation and control module, a trend analysis module, a parameter optimization module and a load closed-loop module. According to the method, frequency characteristics are extracted in a periodic and segmented mode through header power signals, load dynamic sensing is carried out, advancing speed adjustment is more real-time and prospective, response sensitivity and stability are improved in combination with PID control, equipment stably operates at multiple crop densities and plots, the torque increment of a main shaft is monitored in real time, and wavelet transformation multi-scale analysis is carried out; load fluctuation fine-grained identification is carried out, a roller gap and power output are dynamically adjusted to optimize parameters with a minimum mean square error, frequency and torque characteristic closed-loop comparison is constructed, control self-matching and continuous self-adjustment are carried out, error minimization and trend tracking feedback are fused, the intelligence of the harvester is enhanced, and load sudden change performance fluctuation and energy consumption loss are reduced.

Owner:SHANDONG YIJIANONG AGRICULTURAL EQUIPMENT CO LTD
Bionic butterfly ornithopter based on abdomen vibration and compliant mechanism
The invention discloses a bionic butterfly ornithopter based on an abdominal vibration and compliant mechanism. The bionic butterfly ornithopter comprises a fuselage module and a wing module, the machine body module comprises a carbon tube, a head support frame, a chest support frame and a swing rod; a swing flexible hinge is embedded in the chest supporting frame, one end of the swing rod is connected with the head supporting frame through a flexible quadrilateral joint, the other end of the swing rod penetrates out of the swing flexible hinge and extends outwards, and a balancing weight is arranged at the tail of the swing rod. The wing modules are connected with the head supporting frame and the chest supporting frame through flexible joints. The flexible joint is adopted to improve the impact resistance and the self-adjusting capacity, the structural design is simpler and planarized, and the adjustability of mechanism parameters is optimized.

Owner:ZHEJIANG UNIV
High-precision self-adjusting device and method for steel casing installation in torrential water flow
The invention belongs to the technical field of bridge construction, and discloses a high-precision self-adjusting device and method for installing a steel casing in torrential water.The high-precision self-adjusting device comprises a supporting base, a circle center detection device, a plurality of initial positioner sets and a plurality of precise positioner sets, and each initial positioner comprises a sliding plate; guide grooves are formed in the supporting seat, and the sliding plate of each primary positioner extends into one guide groove; each fine positioner comprises a motor, a lead screw mechanism and a contact; the upper computer is connected with the circle center detection device and each motor so as to adjust the actual position of the center line of the steel casing, and the deviation between the actual position of the center line of the steel casing and the design position is within the set threshold value range. According to the method, through a dual positioning mechanism of initial positioning and fine positioning, inclination and deviation of the steel casing caused by installation deviation are effectively avoided, potential safety hazards of engineering quality and structure possibly caused by the installation deviation are reduced, and the overall safety of bridge construction is improved.

Owner:CHINA CONSTRUCTION SIXTH ENGINEERING DIVISION CO LTD +1
High-stability forklift lifting method and system
The invention discloses a high-stability forklift lifting method and system, and relates to the field of logistics carrying. The method is applied to a forklift control system and comprises the following steps: acquiring real-time sensor data of a forklift; the real-time sensor data are input into a plurality of physical field correlation models, a plurality of balance indexes are obtained, and one physical field correlation model corresponds to one balance index; comparing and analyzing the plurality of balance indexes, and determining whether an abnormal balance index exists in the plurality of balance indexes; if yes, correcting the real-time sensor data of the abnormal balance index to obtain corrected sensor data; and the corrected sensor data are sent to the self-adjusting system, so that the lifting mode adjusting accuracy of the self-adjusting system is improved. By implementing the technical scheme provided by the invention, the problem that the forklift shakes and is unbalanced due to errors of the detection precision of the sensor is solved.

Owner:HUBEI JIANGWEI INTELLIGENT AUTOMOBILE LTD BY SHARE LT +1
Full-automatic riveting processing equipment and method for bus duct
The invention relates to the technical field of bus duct processing, in particular to a full-automatic riveting processing device and method for a bus duct. Comprising a rack; the transmission module is horizontally arranged on the rack in the long side direction of the rack, and the transmission module is provided with a first guide unit and a second guide unit which can be relatively and horizontally adjusted in a sliding mode; the number of the riveting modules is two, and the two riveting modules are oppositely arranged on the rack in a vertical state; the riveting module is provided with a riveting head capable of riveting the bus duct and the PE layer and a first linear driver capable of controlling the riveting depth of the riveting head; the offset detection module is horizontally arranged on one side of the transmission module in the transmission direction of the transmission module; the offset correction module is horizontally arranged on the rear side of the offset detection module in the transmission direction of the transmission module; according to the automatic riveting device, the riveting depth can be automatically adjusted according to different materials, and the deviated PE plate can be adjusted in real time.

Owner:FUMI ELECTRIC CO LTD
Robot joint torque self-adjusting control system based on deep learning
The invention relates to the technical field of robot control, in particular to a robot joint torque self-adjustment control system based on deep learning, which comprises a robot main body, an environment perception and coordinate construction module, a deep learning torque modeling module, a path planning and torque presetting module, a real-time feedback correction module and a multi-joint collaborative optimization module. And data interaction among the modules is realized through a CAN-Ethernet hybrid bus. In the scheme, through cooperative acquisition of the laser radar, the depth camera, the joint force sensor and the IMU, and in combination with conversion of a world coordinate system, a main body coordinate system and a joint local coordinate system, integration of environment characteristics and motion parameters under a unified framework is realized. By means of the design, torque deviation caused by non-uniform coordinates or data fragmentation is avoided, torque control can better fit the actual environment and the state of the robot, the overall accuracy of torque control is improved from the basic level, and the precise requirement for torque calculation in a complex scene is met.

Owner:GUANGDONG DESHENG INTELLIGENT TECHNOLOGY CO LTD
Sectional type self-adjusting control wet clutch
The invention relates to a sectional type self-adjusting control wet clutch, which belongs to the technical field of automatic gearboxes, and comprises a transmission shaft and a clutch piston cylinder, a piston is arranged in a piston cavity of the clutch piston cylinder, the acting surface of the piston is divided into an inner acting surface and an outer acting surface, and a baffle ring is arranged in the clutch piston cylinder. The piston cavity is divided into a first cavity body and a third cavity body by the baffle ring, the first cavity body is communicated with a main oil duct in the transmission shaft, and the inner acting surface and the outer acting surface are respectively positioned in the first cavity body and the third cavity body; a mounting hole extending in the radial direction is further formed in the clutch piston cylinder, a plurality of through holes are formed between the mounting hole and the piston cavity and include a first throttling hole, a second throttling hole, a third throttling hole and a second oil drainage hole, and the clutch piston cylinder is further provided with a first oil drainage hole communicated with the mounting hole. A gear shifting auxiliary control valve is arranged in the mounting hole and comprises a base, a valve piston, a valve rod and a valve sleeve which are sequentially arranged. Auxiliary adjustment of each control stage of the clutch in the gear shifting process can be achieved.

Owner:LUOYANG REASTAR TRANSMISSION
Self-adjusting preload for memory alloy wire
ActiveUS12365518B2Non-mechanical controlsConstruction fastening devicesOffset distanceClassical mechanics
A preload mechanism for an actuator is disclosed that includes a rotating element configured to rotate about a pivot. The preload mechanism also includes a bias element with a first end that is coupled to a second contact point of the rotating element and a second end configured to be pinned relative to the pivot. The bias element has a line of action extending from the second end through the first end. The line of action has an offset distance that is the minimum distance between the line of action and the pivot. The offset distance has a first value when the rotating element is in the first position and a second value when the rotating element is the second position, the second value being smaller than the first value.

Owner:CAREFUSION 303 INC
Intelligent self-adjusting construction platform
The utility model discloses an intelligent self-adjusting construction platform which comprises a lifting platform, the lifting platform comprises a platform capable of walking, a lifting mechanism is assembled on the top of the platform, a self-adjusting mechanism is assembled on the top of the lifting mechanism, and a carrying hopper is assembled on the top of the self-adjusting mechanism. The intelligent self-adjusting construction platform can automatically detect the balance degree of the personnel carrying hopper of the construction platform and automatically adjust the balance degree, when the intelligent self-adjusting construction platform is used, internal equipment of the platform drives the hydraulic cylinder to stretch out and draw back, and therefore changes of the horizontal crossing distance between the hinge rods are driven to control changes of the hinge rods in the vertical direction. When the carrying hopper is unbalanced, the detection device is matched with the control module to control and adjust the position change of the balancing weight to drive the carrying hopper to be balanced again, so that the operation safety of the construction platform is ensured, and the problem that when an existing construction platform ascends, the carrying hopper is damaged is effectively solved. And the change of the center of gravity of the top influences the overall safety of the equipment.

Owner:济南一建集团有限公司
Self-adjusting locking piece for a locking unit
A locking piece for a locking unit includes a housing having a housing opening. A locking arm, which engages through the housing opening, is mounted so as to be displaceable, in a direction at a right angle to its longitudinal direction, in the housing opening. A slide is guided displaceably in the housing in the displacement direction of the locking arm and is motion-coupled to the locking arm in the displacement direction. The housing and / or the slide are / is formed from magnetically attractable material. At least one magnet acts between the housing and slide and positionally fixes the locking arm in each possible displacement position within the housing opening.

Owner:HAEFELE TECHNOLOGY SOLUTIONS GMBH & CO KG
Contact device and relay
The invention relates to the technical field of electronic control devices, in particular to a contact device and a relay. The contact device comprises: a static contact group, wherein the static contact group comprises two static contacts; the movable spring assembly comprises a movable spring, and the two ends of the movable spring can move relative to the static contact group, so that the two ends of the movable spring are in contact with or separated from the static contact group; the elastic piece is arranged on one side, deviating from the static contact group, of the movable spring assembly; and an arc-shaped contact surface is arranged between the elastic piece and the movable spring assembly. The contact device can realize the self-adjustment of the movable spring in the movable spring assembly at any position, so that the movable spring and the static contact reach a contact balance point, the effective use of the relay is ensured, and the performance of the relay is improved.

Owner:XIAMEN HONGFA ELECTRIC POWER CONTROLS CO LTD
Transmission drum structure and belt conveyor thereof
The invention relates to the technical field of belt conveyor rollers, in particular to a transmission roller structure and a belt conveyor thereof, the transmission roller structure comprises a rack, and the rack is connected with a roller body; the driving assembly is used for driving the roller main body to rotate; the friction assembly is used for enhancing the friction force between the belt and the roller; the tensioning force self-adjusting assembly comprises an inertia energy storage mechanism, a vibration energy storage mechanism, a storage mechanism and an adjusting mechanism; and the cleaning assembly is used for cleaning the friction assembly by using the air in the storage mechanism. Inertial energy and vibration energy of roller movement are converted into compressed air to be stored through the inertial energy storage mechanism and the vibration energy storage mechanism, the friction assembly is dynamically adjusted in combination with the adjusting mechanism, self-adaptive adjustment of friction force is achieved, belt slipping is effectively avoided, and the conveying reliability is improved.

Owner:ZHEJIANG BAOKE MACHINERY
Wall body detection device for architectural design
ActiveCN120740533AApparatus for force/torque/work measurementMechanical measuring arrangementsPressure transmissionLinkage (mechanical)
The invention discloses a wall detection device for architectural design, and relates to the technical field of wall detection, the wall detection device comprises a detection main frame body, a first motor and a second motor are symmetrically mounted on the upper surface of the bottom of the detection main frame body, and output shafts of the first motor and the second motor are fixedly connected with a lifting mechanism; the wall detection device for architectural design further comprises a pressure gauge and three contact wheels which are arranged in an arc shape to form an integral contact surface, the transverse moving mechanism is linked with the lifting mechanism to perform multi-area detection on the wall, and when the pressure adjusting mechanism performs movement detection in the vertical and horizontal directions, the pressure adjusting mechanism can adjust the pressure in the vertical and horizontal directions. The abutting wheels conduct abutting type elastic pressure self-adjustment on the radian of the wall and feed pressure elasticity back to the pressure gauge, the auxiliary deformation mechanism is matched with the radian through elastic deformation of the center and the abutting wheels on the two sides, and the comprehensive pressure of the abutting wheels on the wall is transmitted to the pressure gauge. The multi-dimensional cooperative detection optimization effect of a mechanical structure, pressure feedback and motion control is achieved.

Owner:SICHUAN LEDAO ZHITONG CONSTRUCTION ENGINEERING CO LTD