
Patents
Literature
43results about How to "Reduce cables" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
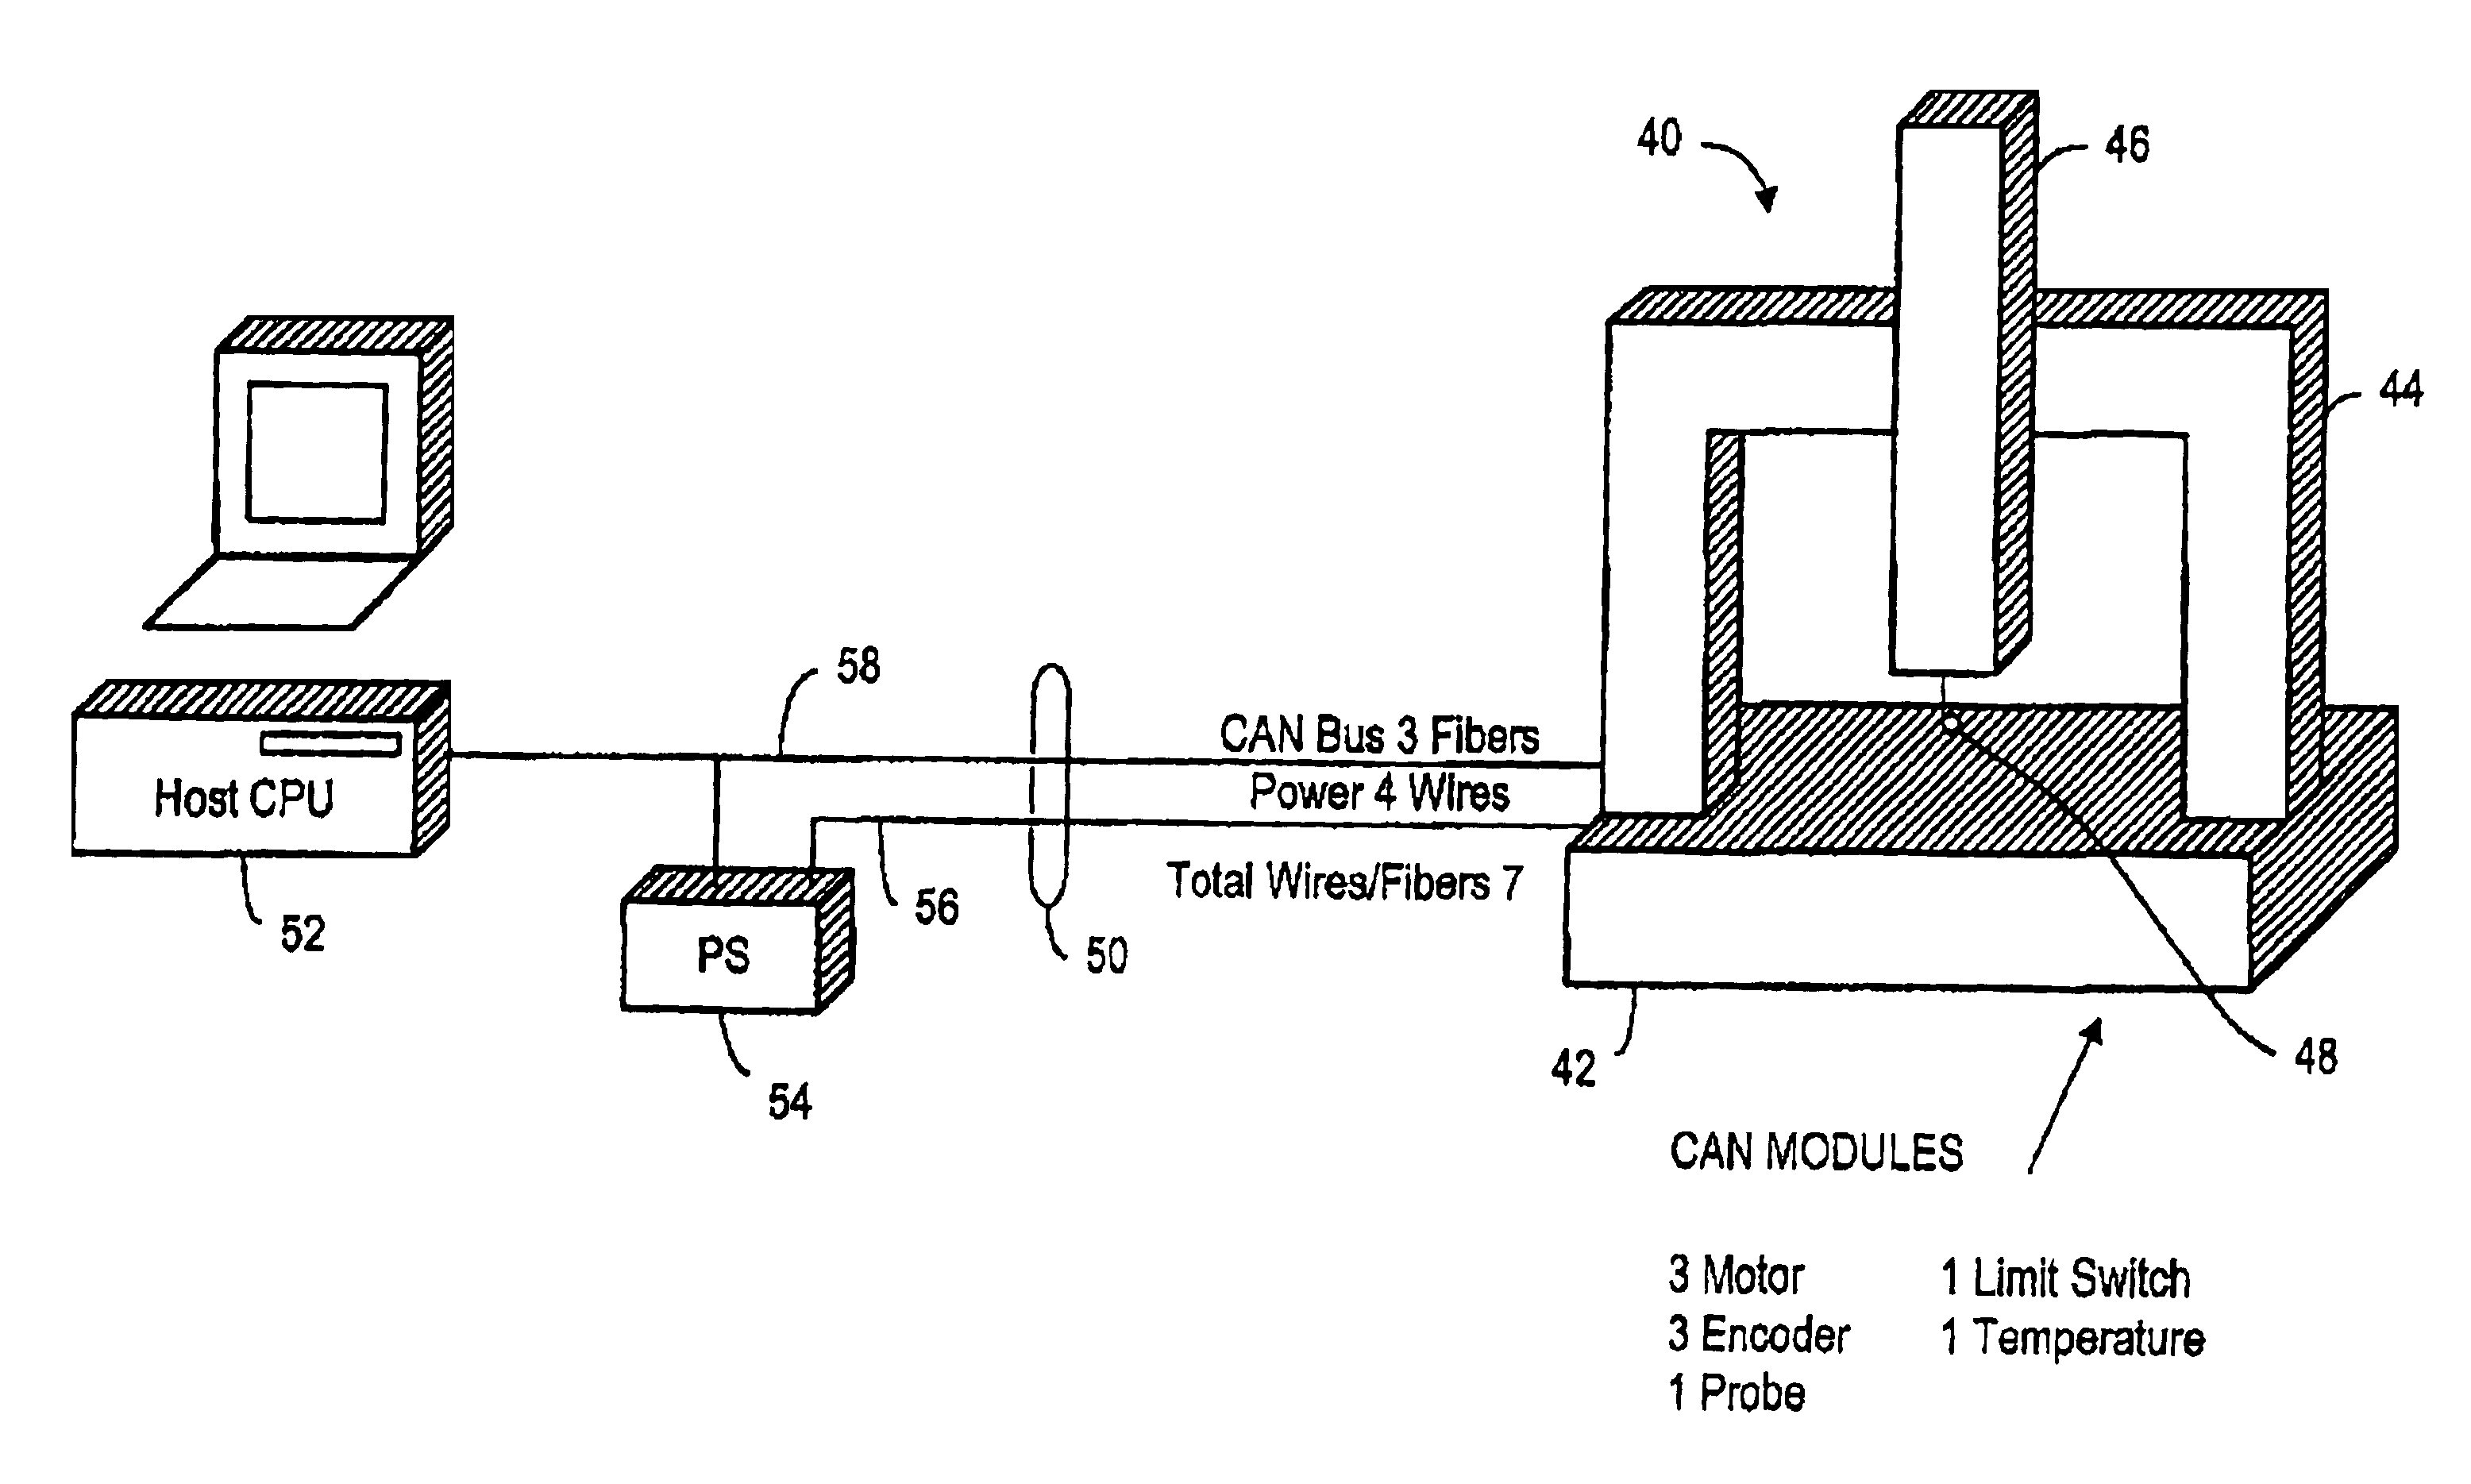
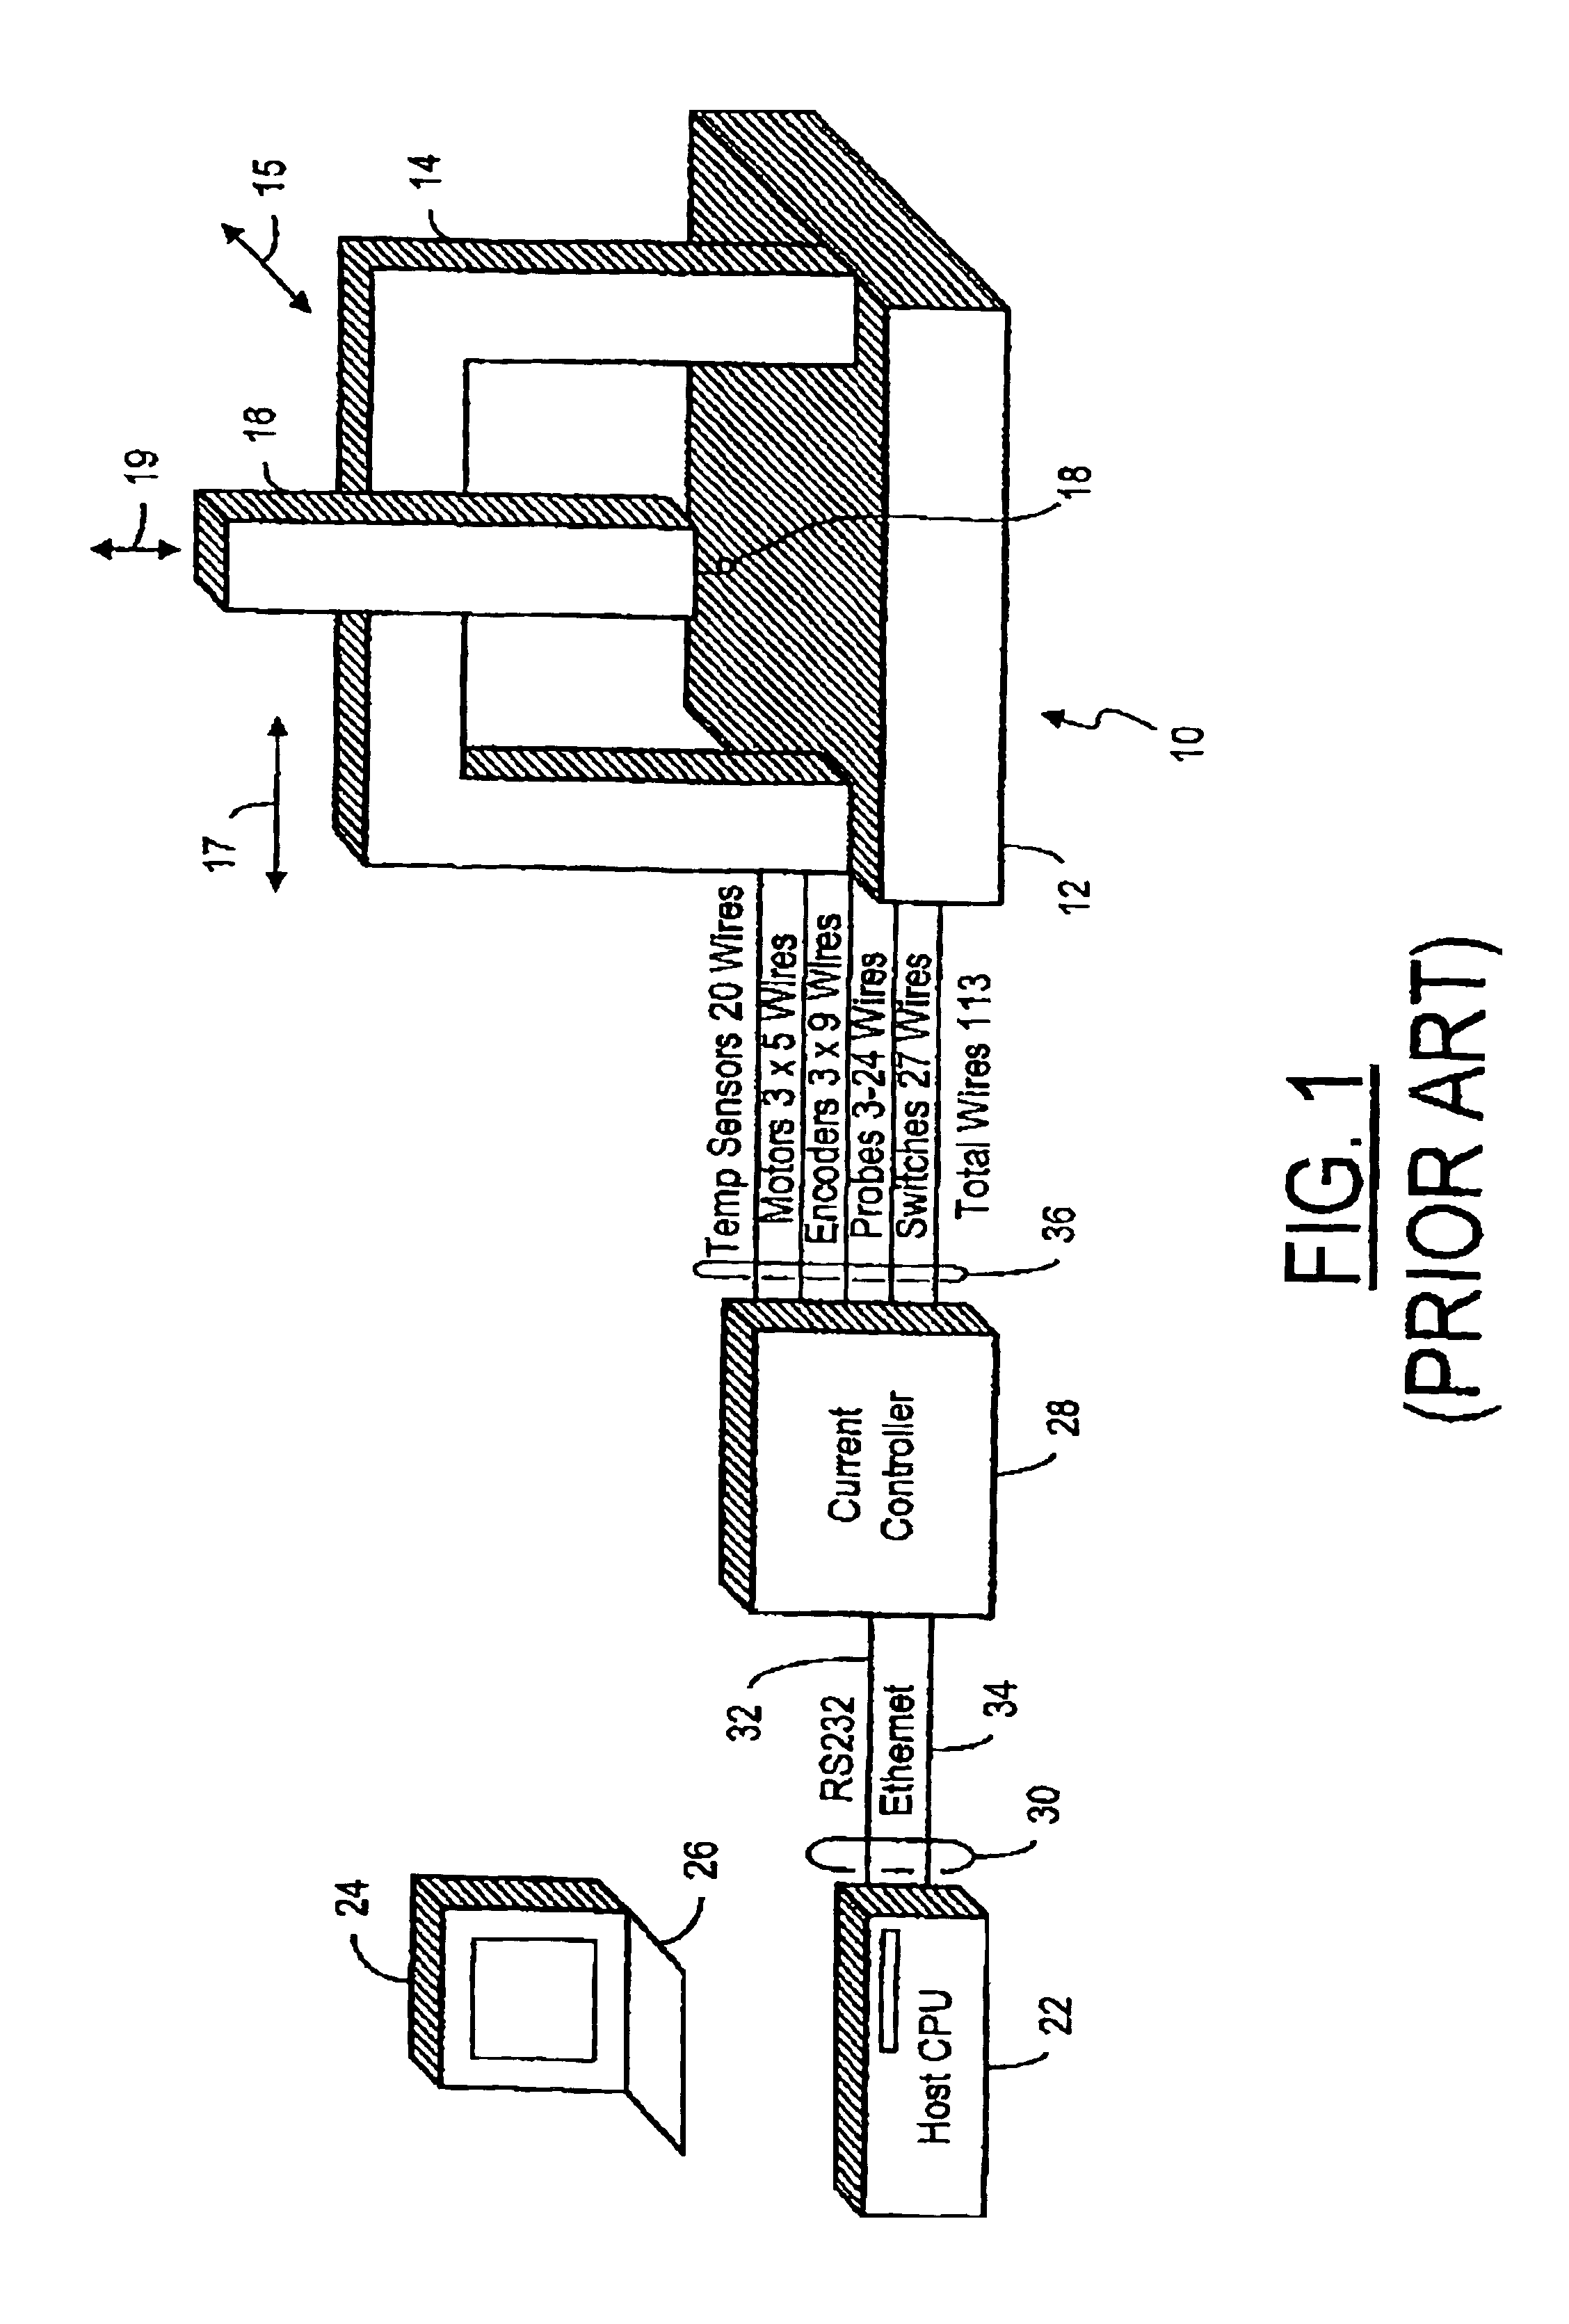
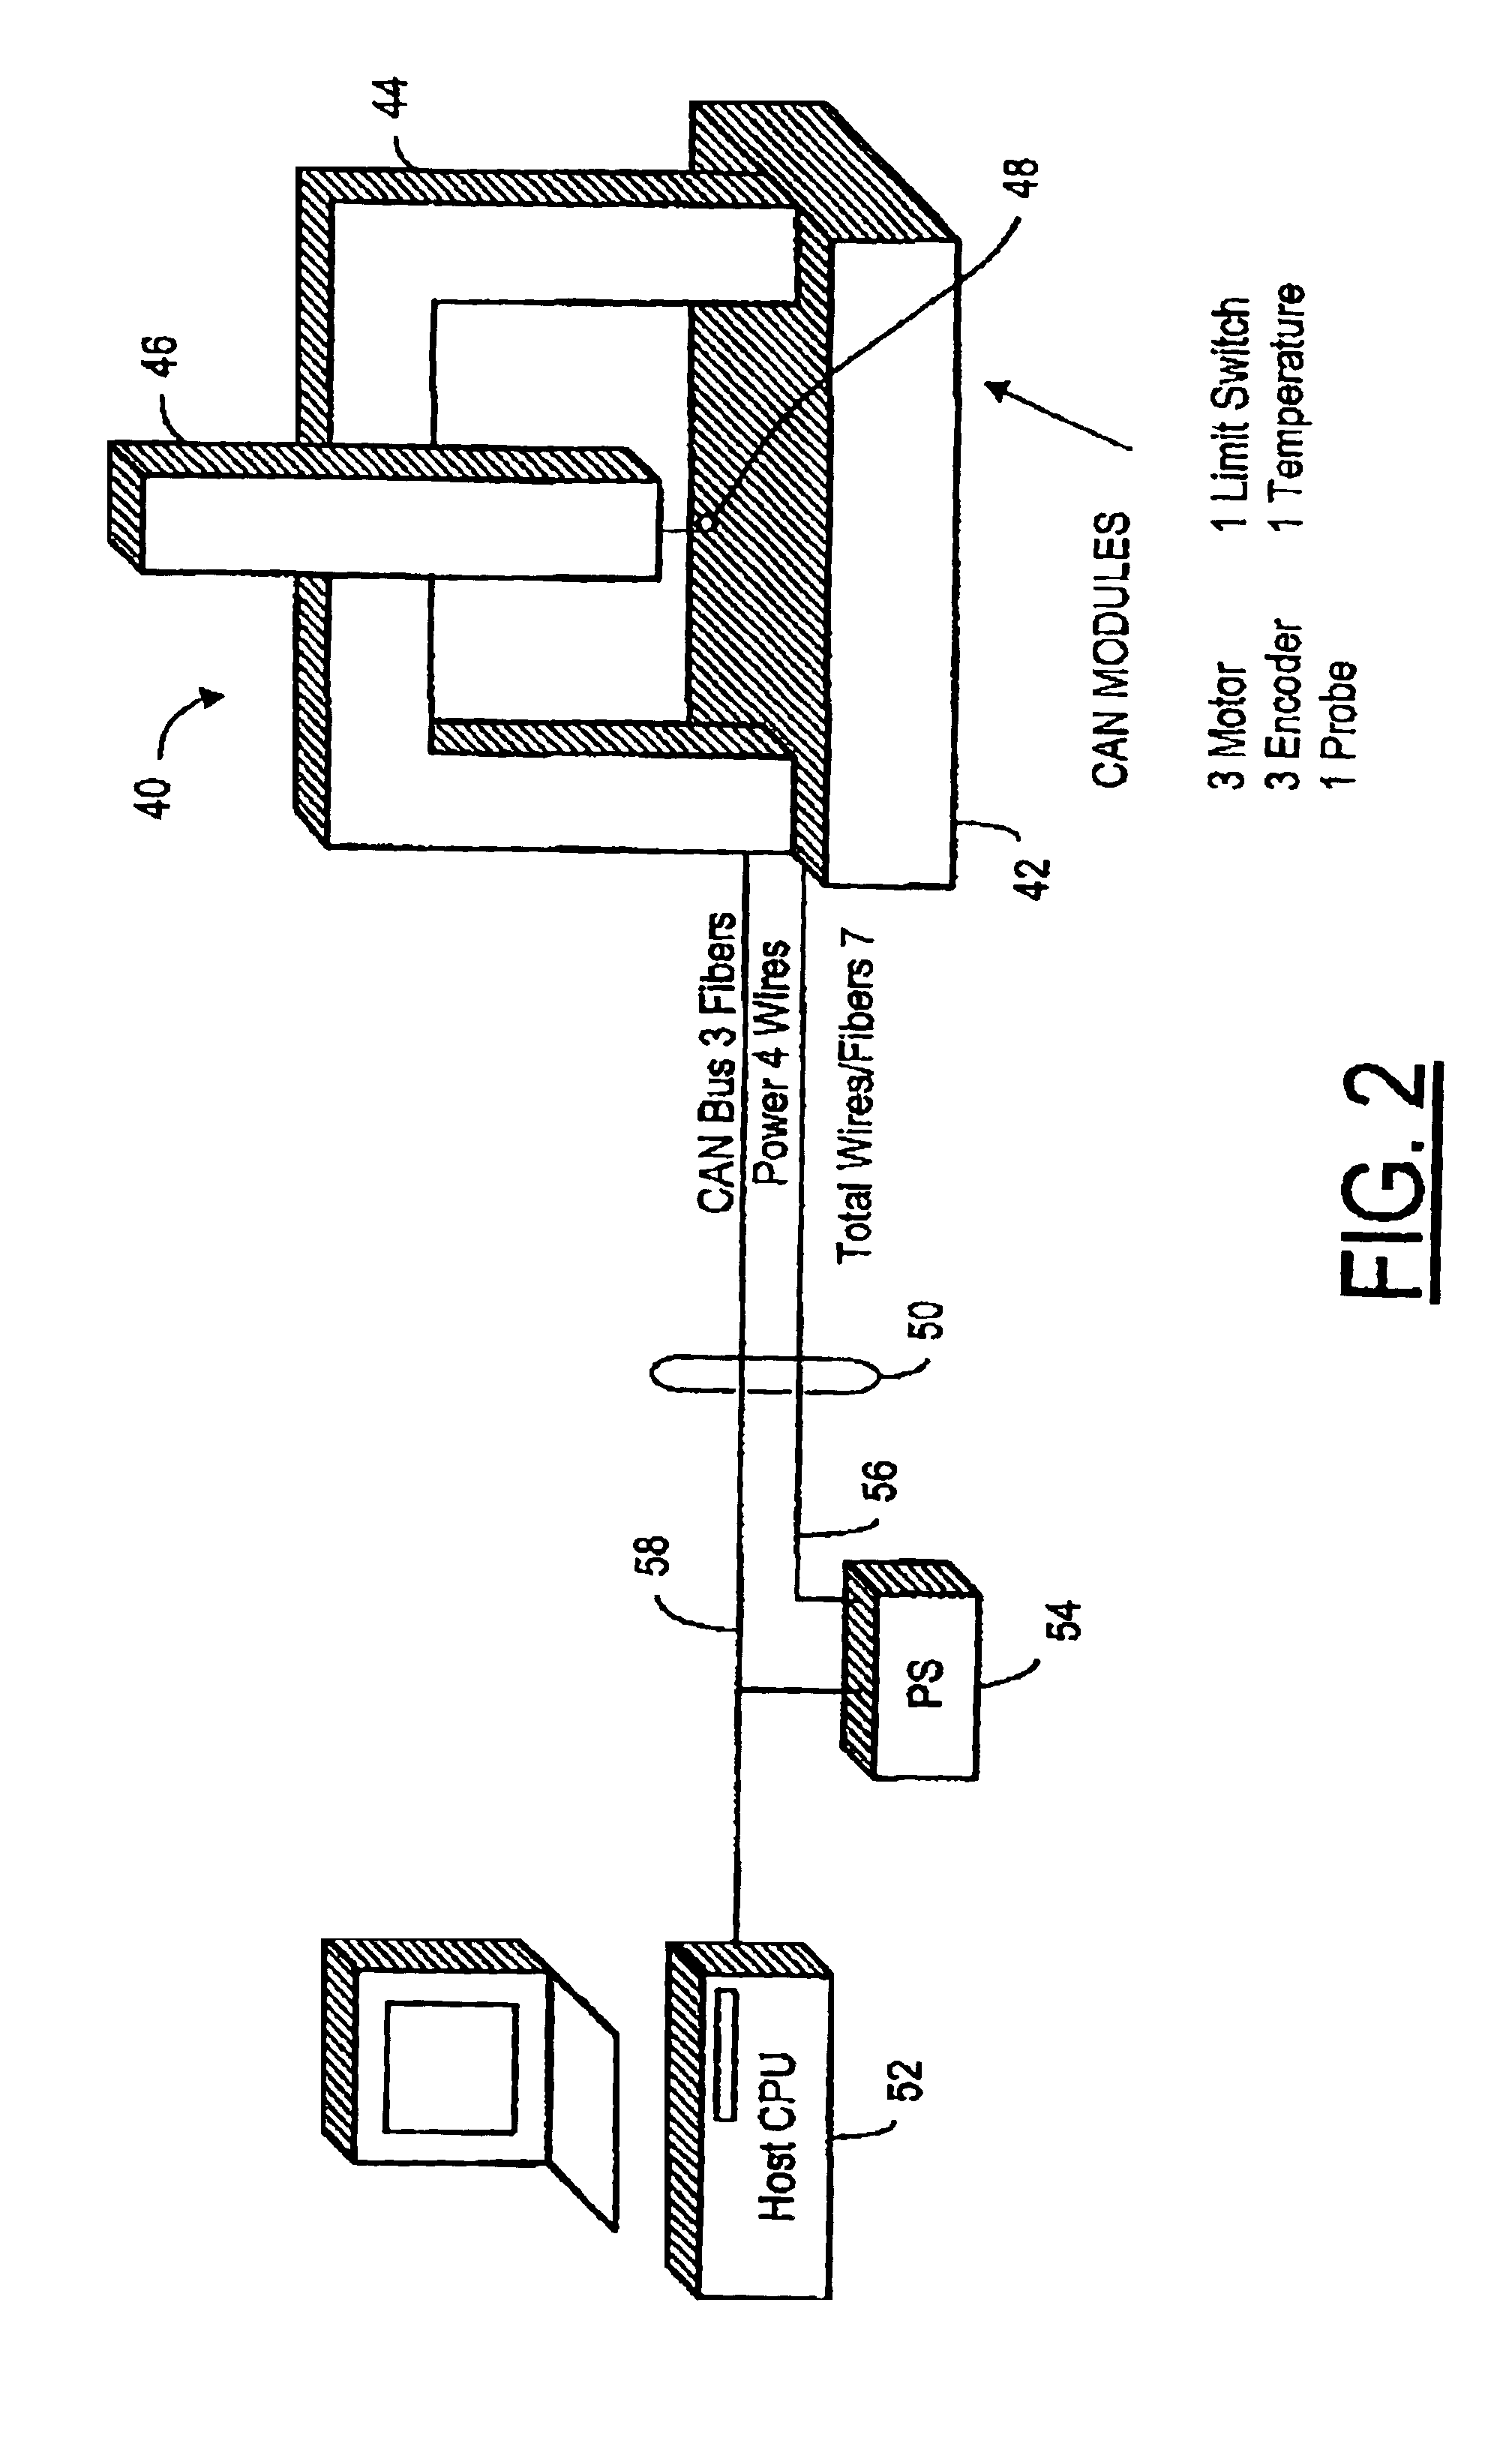
Communication method and common control bus interconnecting a controller and a precision measurement assembly
InactiveUS6948255B2Reduce cable dragImprove servo performanceFeeler-pin gaugesUsing subsonic/sonic/ultrasonic vibration meansControl busEmbedded system
The number and weight of wires interconnecting a host and / or controller with a precision measurement assembly is reduced using a common or shared bus. The bus may be entirely electrical or may include optical fibers to reduce EMI susceptibillty. A custom bus or a known serial network bus such as CAN or SIRCOS may be used.
Owner:HEXAGON TECH CENT GMBH
Electrical distribution box for vehicles having two networks with different voltage levels
InactiveUS6879057B1Reduce cablesReduce occupied volumeSubstation/switching arrangement detailsElectric devicesVoltage converterElectricity
An electrical distribution box for vehicles with two networks at different voltage levels, comprising centralized electronic signal and power control means, including a microprocessor and electrical protection means, arranged on printed circuit boards in a casing, electrically connected to at least one DC supply source and to parts of the vehicle, incorporating at least one voltage converter (5) inside the distribution box (1), on an independent printed circuit board (10) or in a differentiated area of a supporting plate of the control means, which board (10) or differentiated area is in a clear area of said casing, both in its upper part and in its lower part, electromagnetic screening means having been provided for the converter (5) inside the casing, and thermal dissipation means for the supporting plate of the converter (5).


Owner:LEAR AUTOMOTIVE (EEDS) SPAIN SL
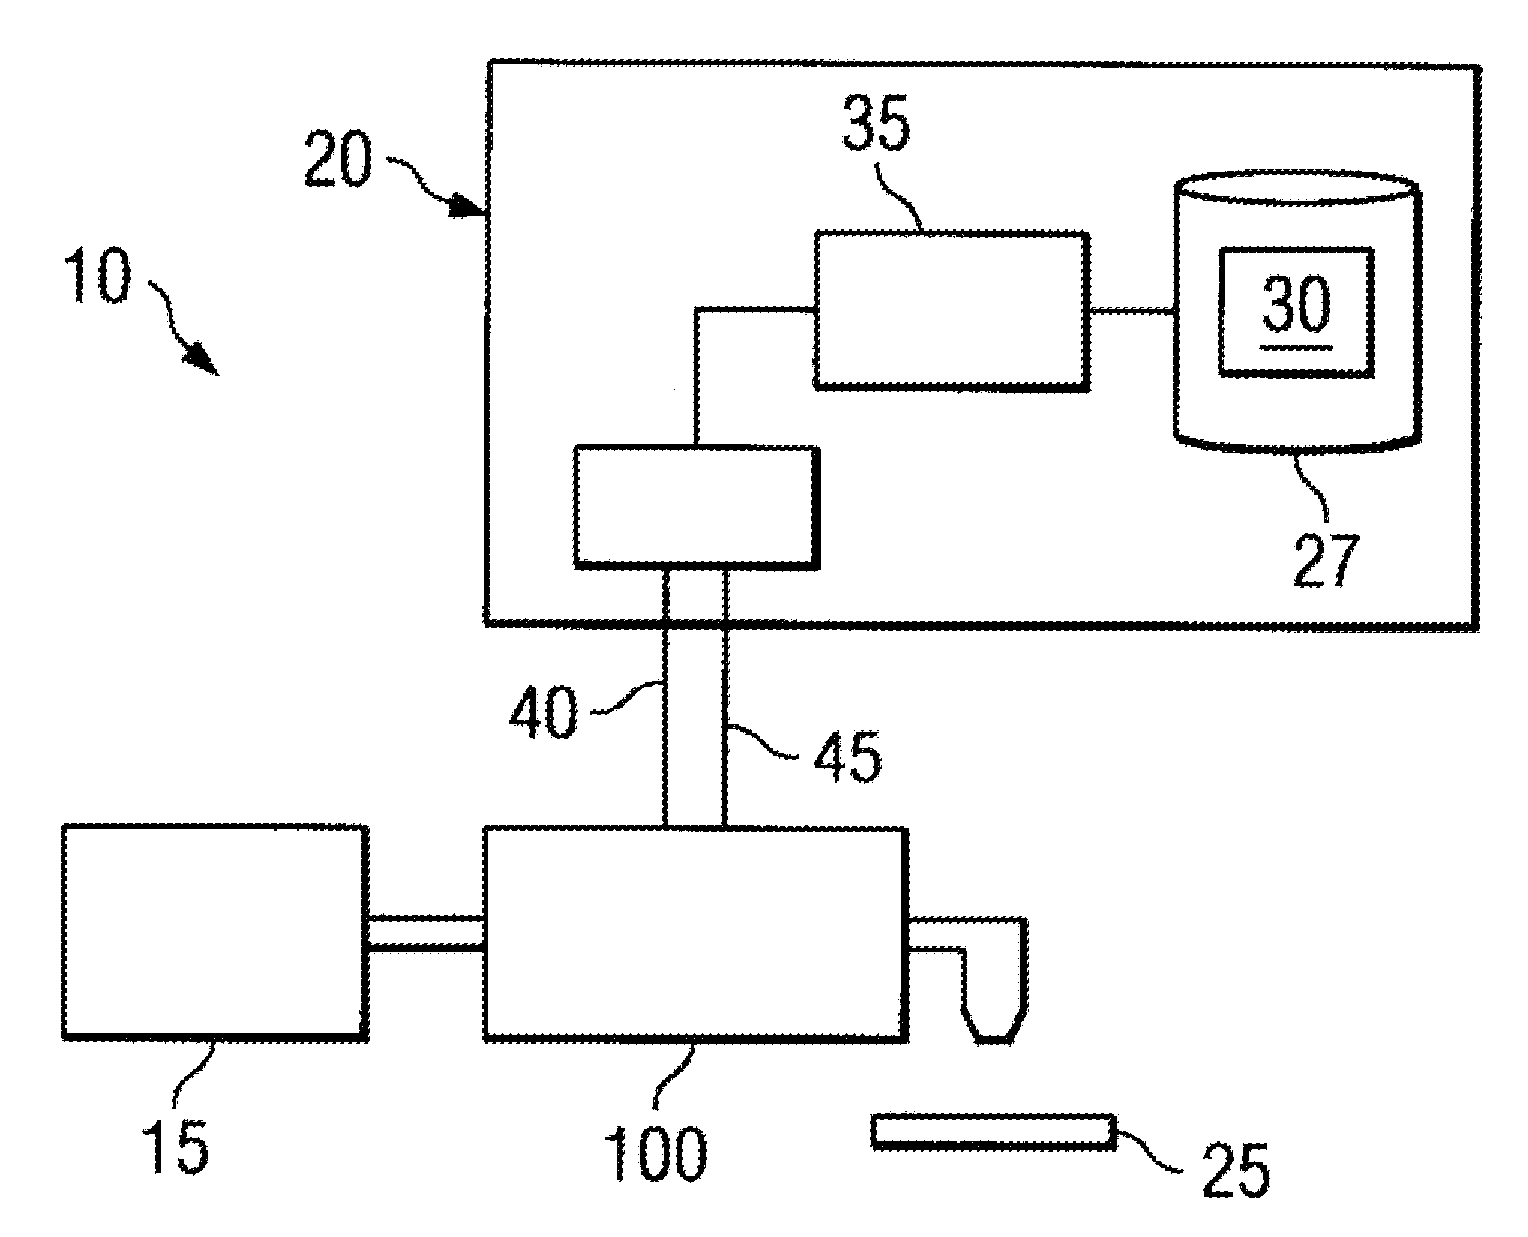
I/O systems, methods and devices for interfacing a pump controller
ActiveUS7940664B2Reduce in quantityReduce cablesProgramme controlError preventionCommunication interfaceNetwork packet
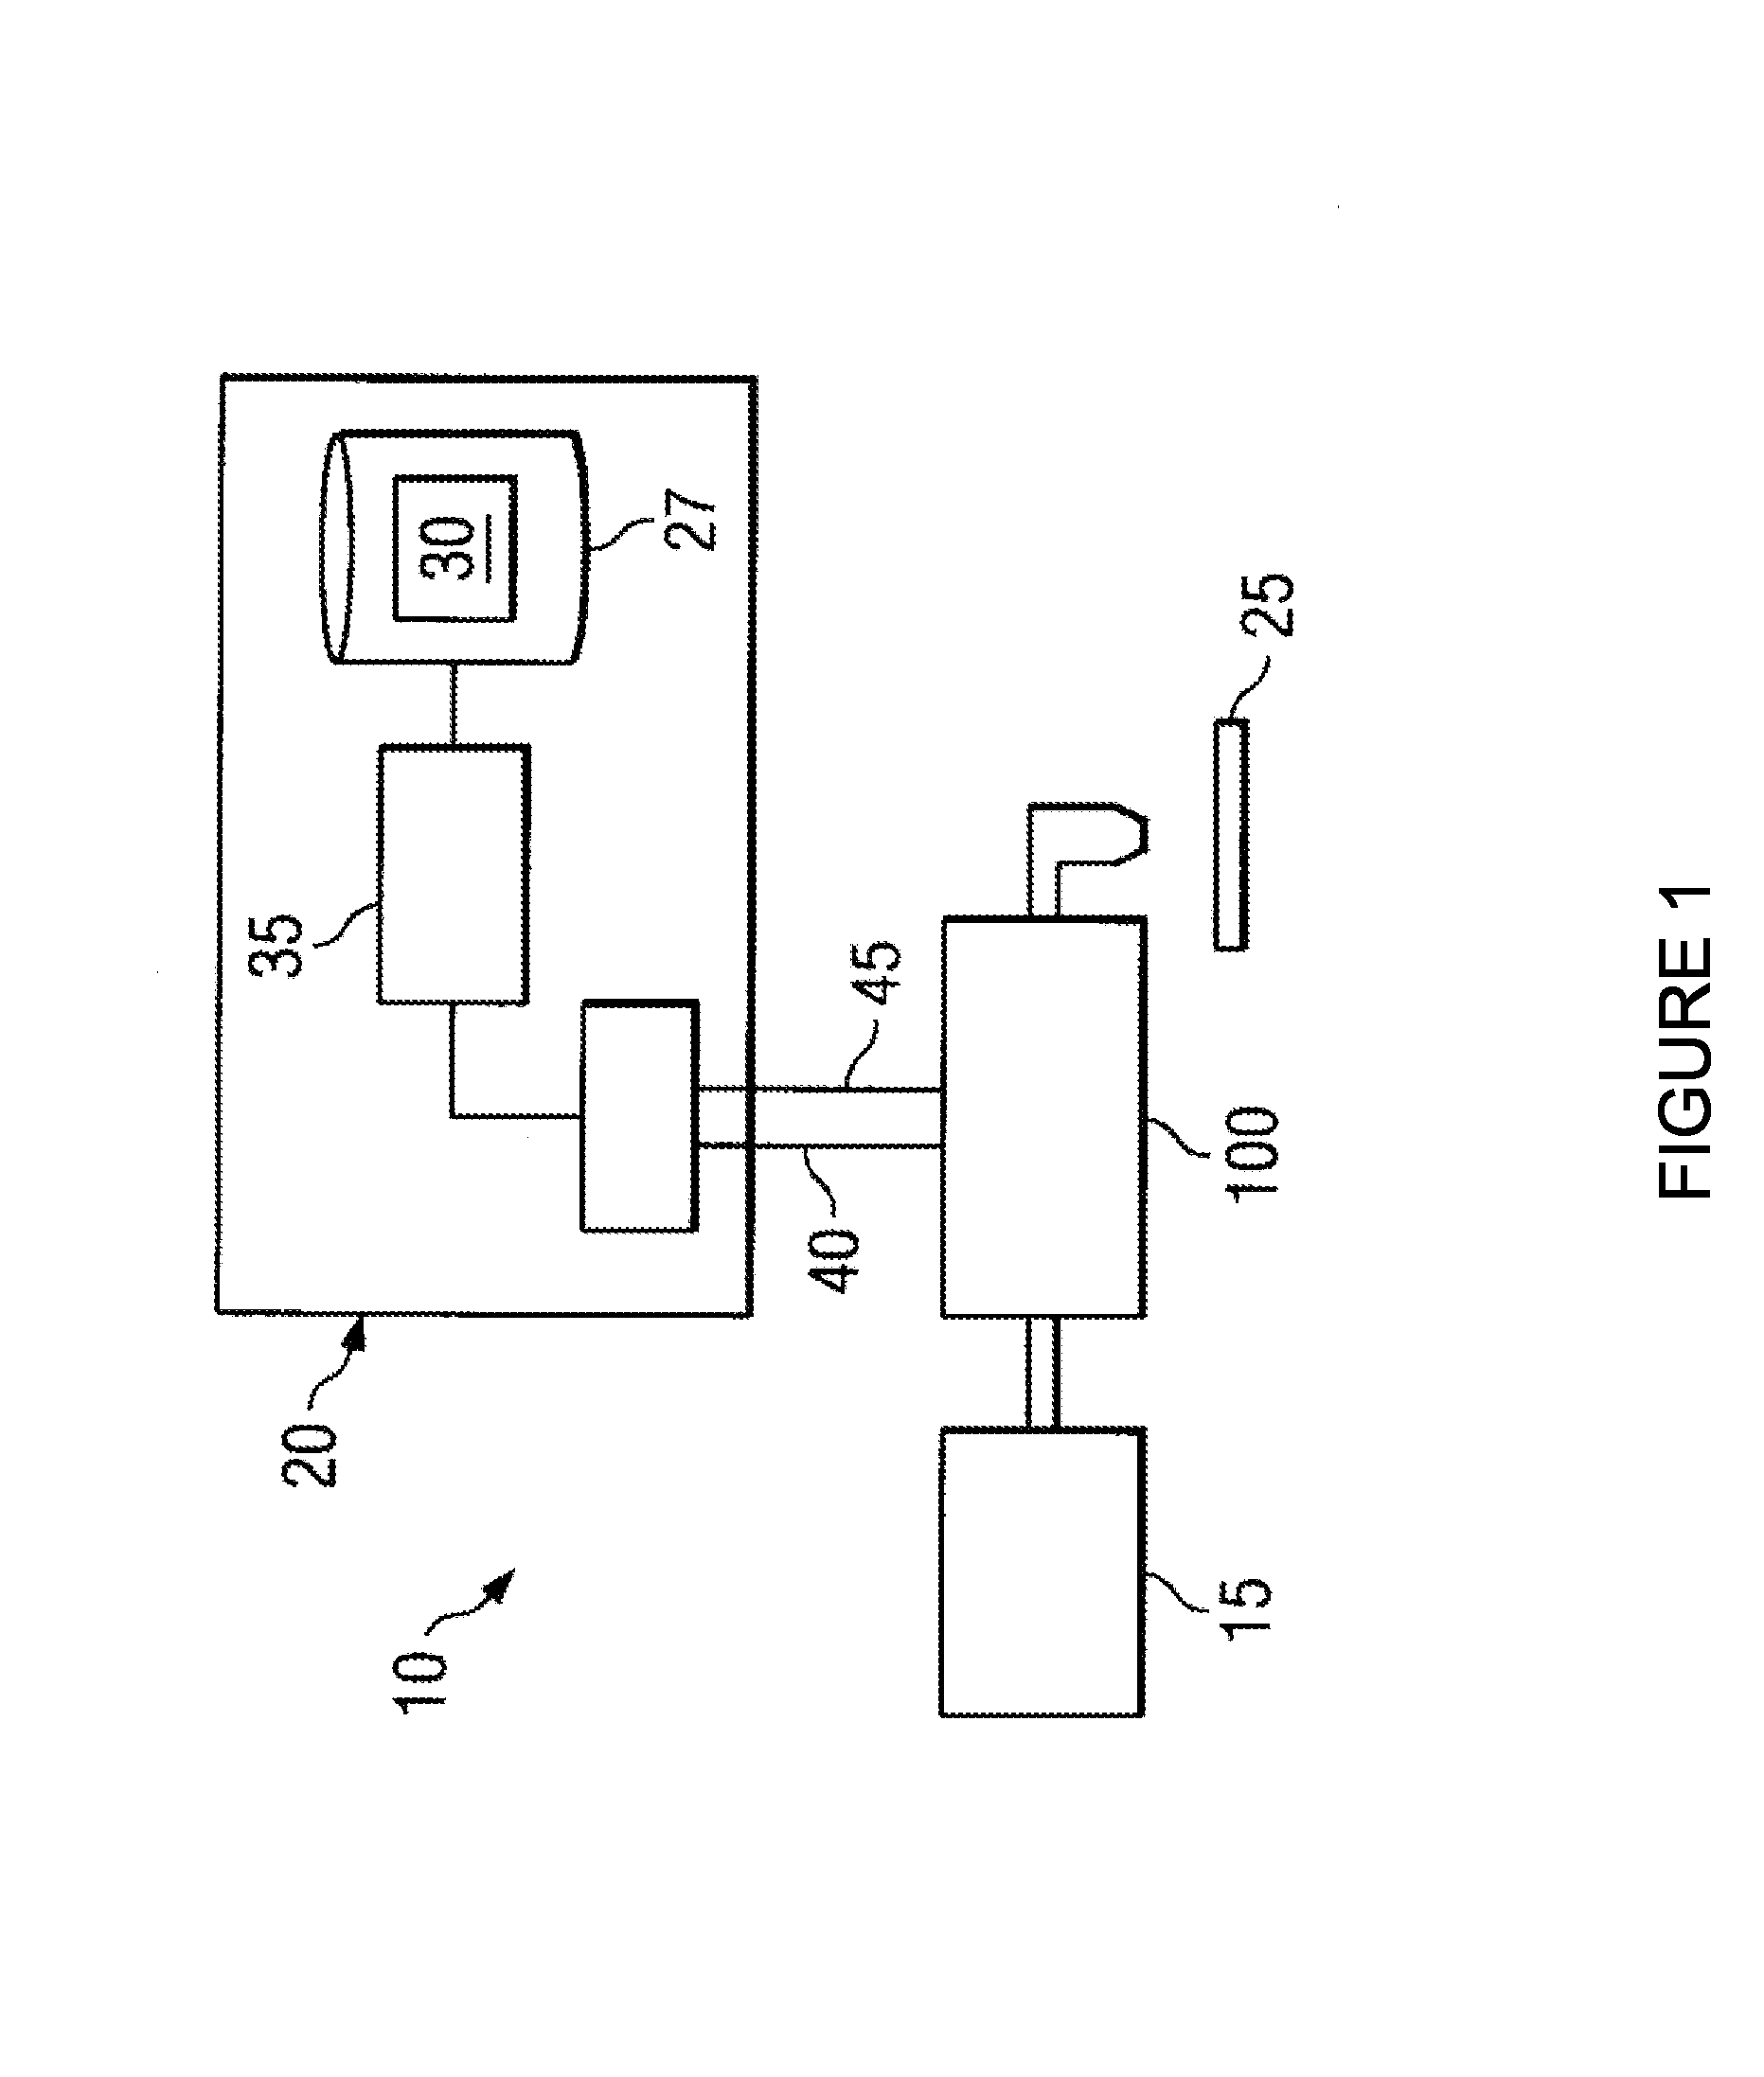
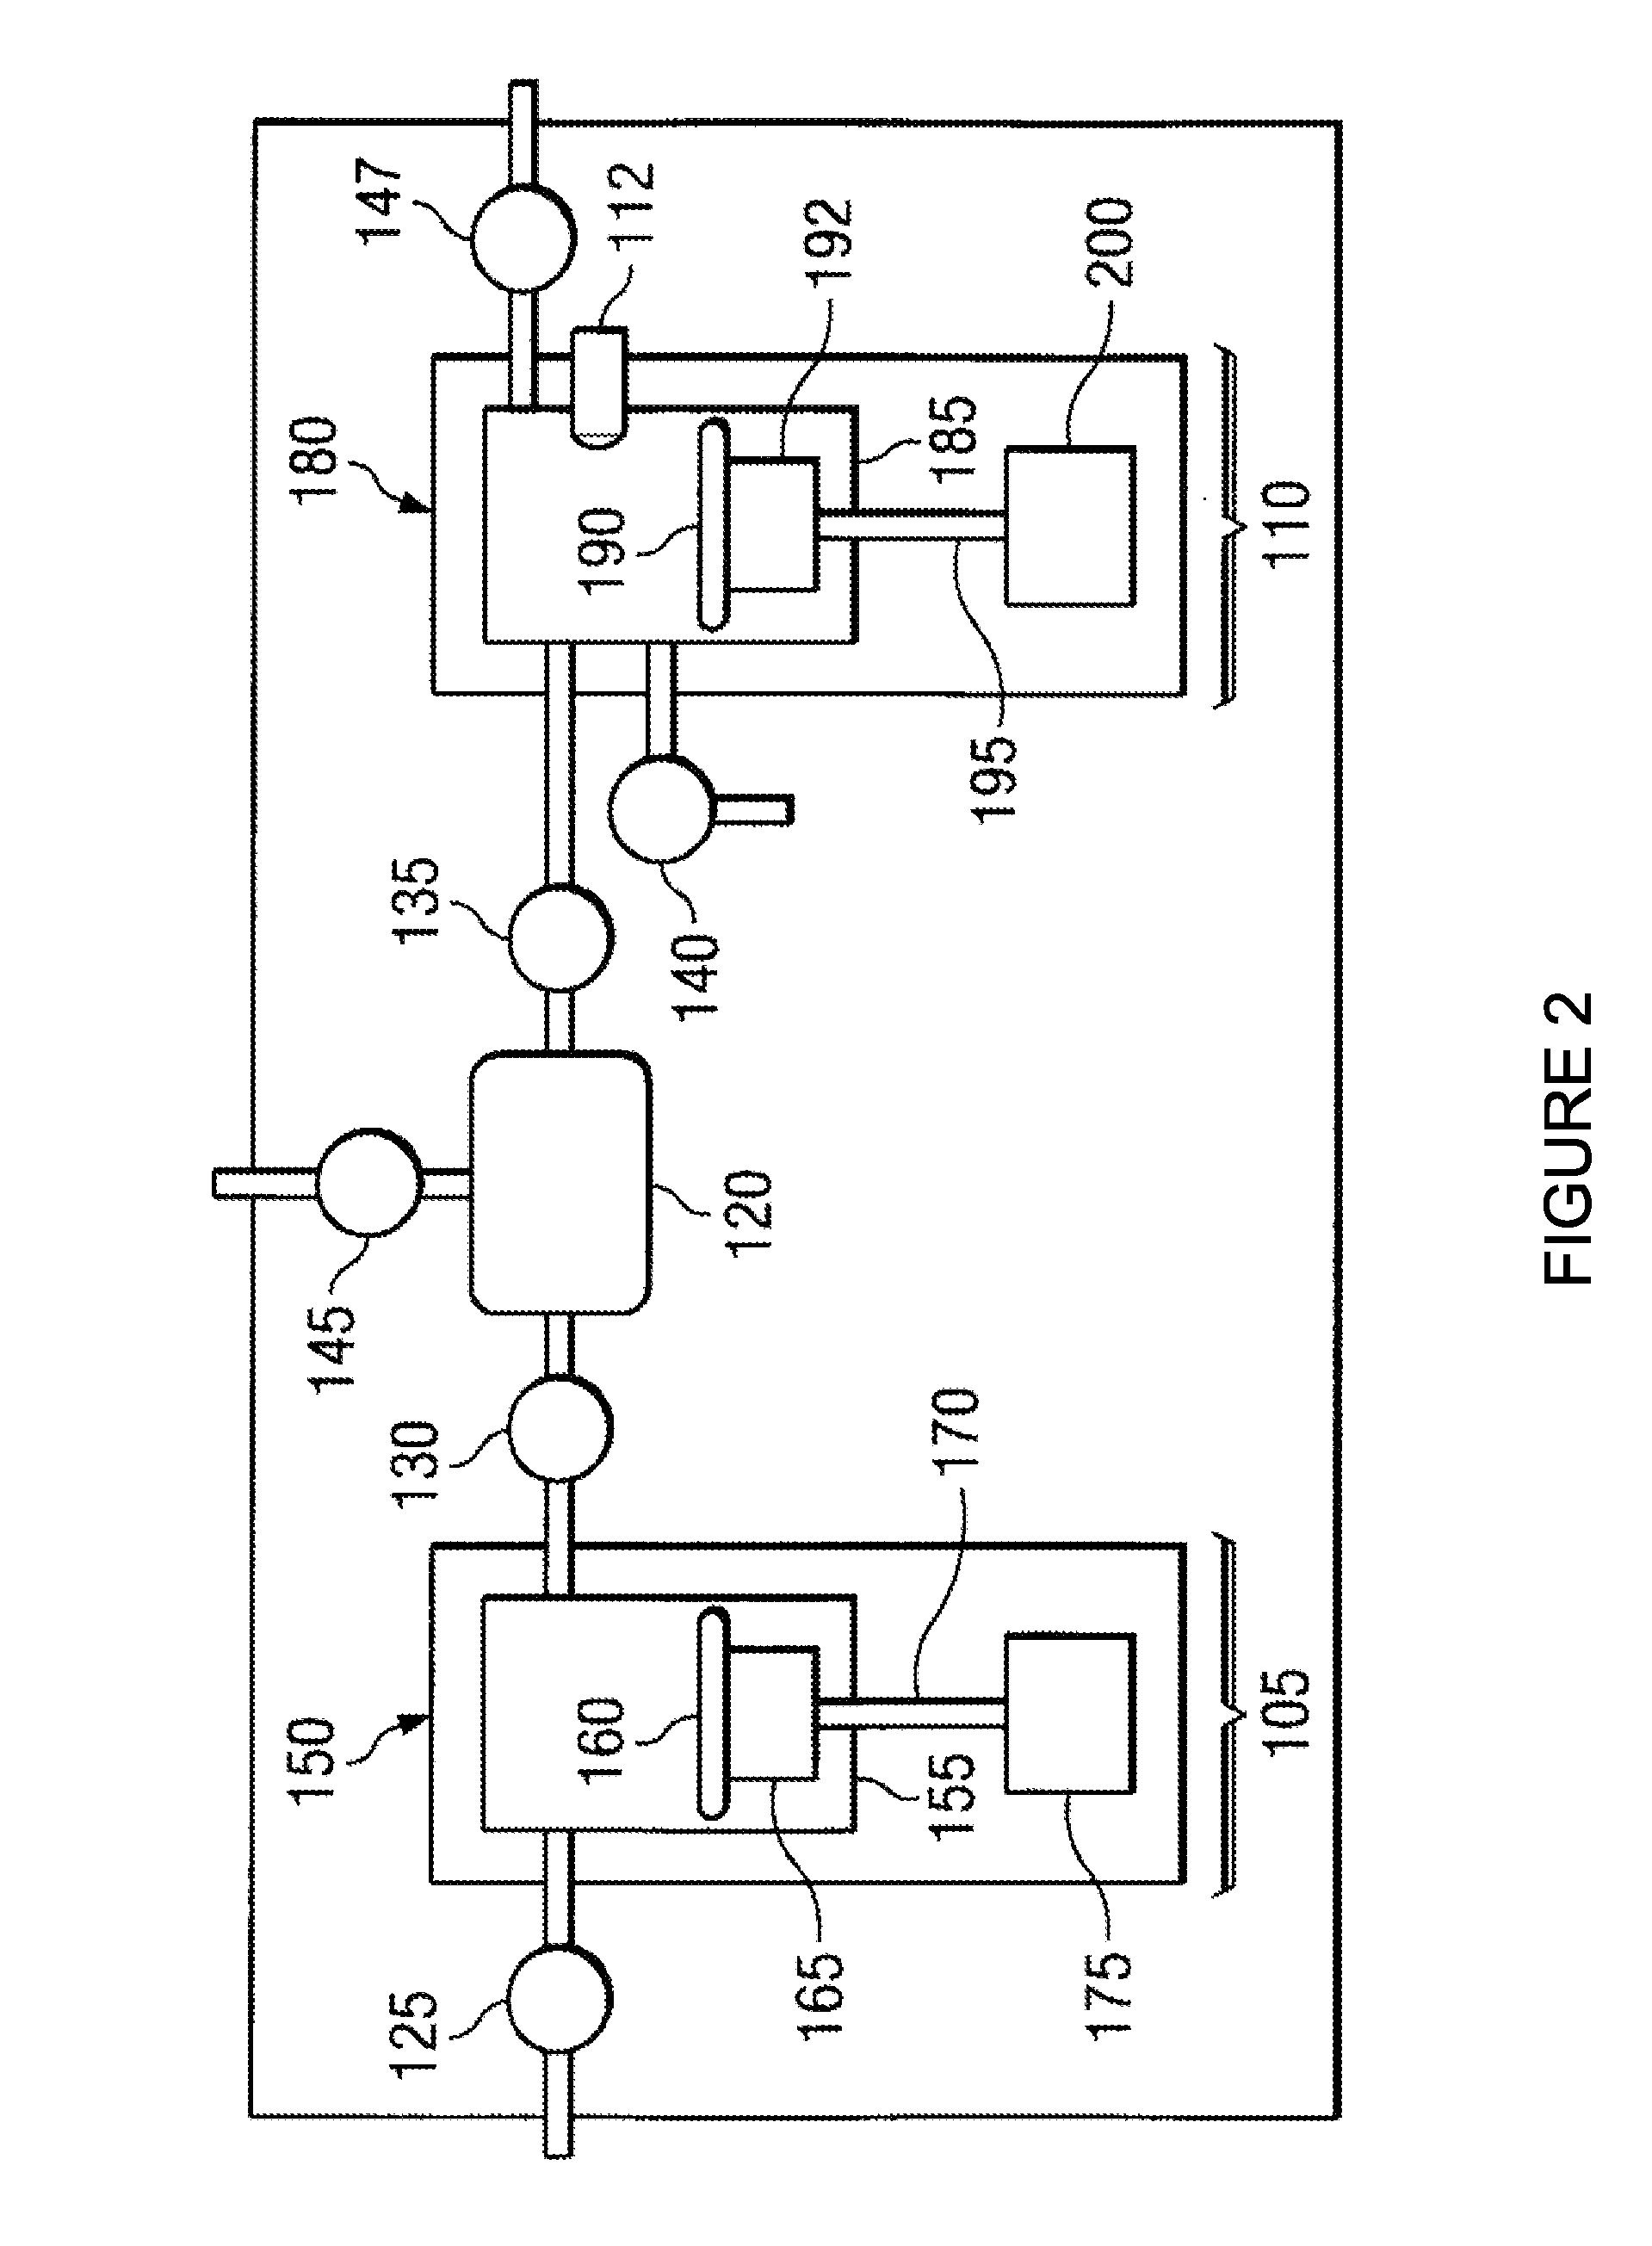
Embodiments of the present invention provide I / O systems, methods, and devices for interfacing pump controller(s) with control device(s) which may have different interfaces and / or signaling formats. In one embodiment, an I / O interface module comprises a processor, a memory, and at least two data communications interfaces for communicating with a pumping controller and a control device. The I / O interface module can receive discrete signals from the control device, interpret them accordingly and send the packets to the pump controller. The pump controller reads the packets and takes appropriate actions at the pump. The I / O interface module can interpret packets of data received from the pump controller and assert corresponding discrete signals to the control device. The I / O interface module is customizable and allows a variety of interfaces and control schemes to be implemented with a particular multiple stage pump without changing the hardware of the pump.
Owner:ENTEGRIS INC
Modular Connected Headrest
InactiveUS20150381941A1The process is simple and fastEliminate additional antennasSeat coveringsTelevision system detailsViewpointsModularity
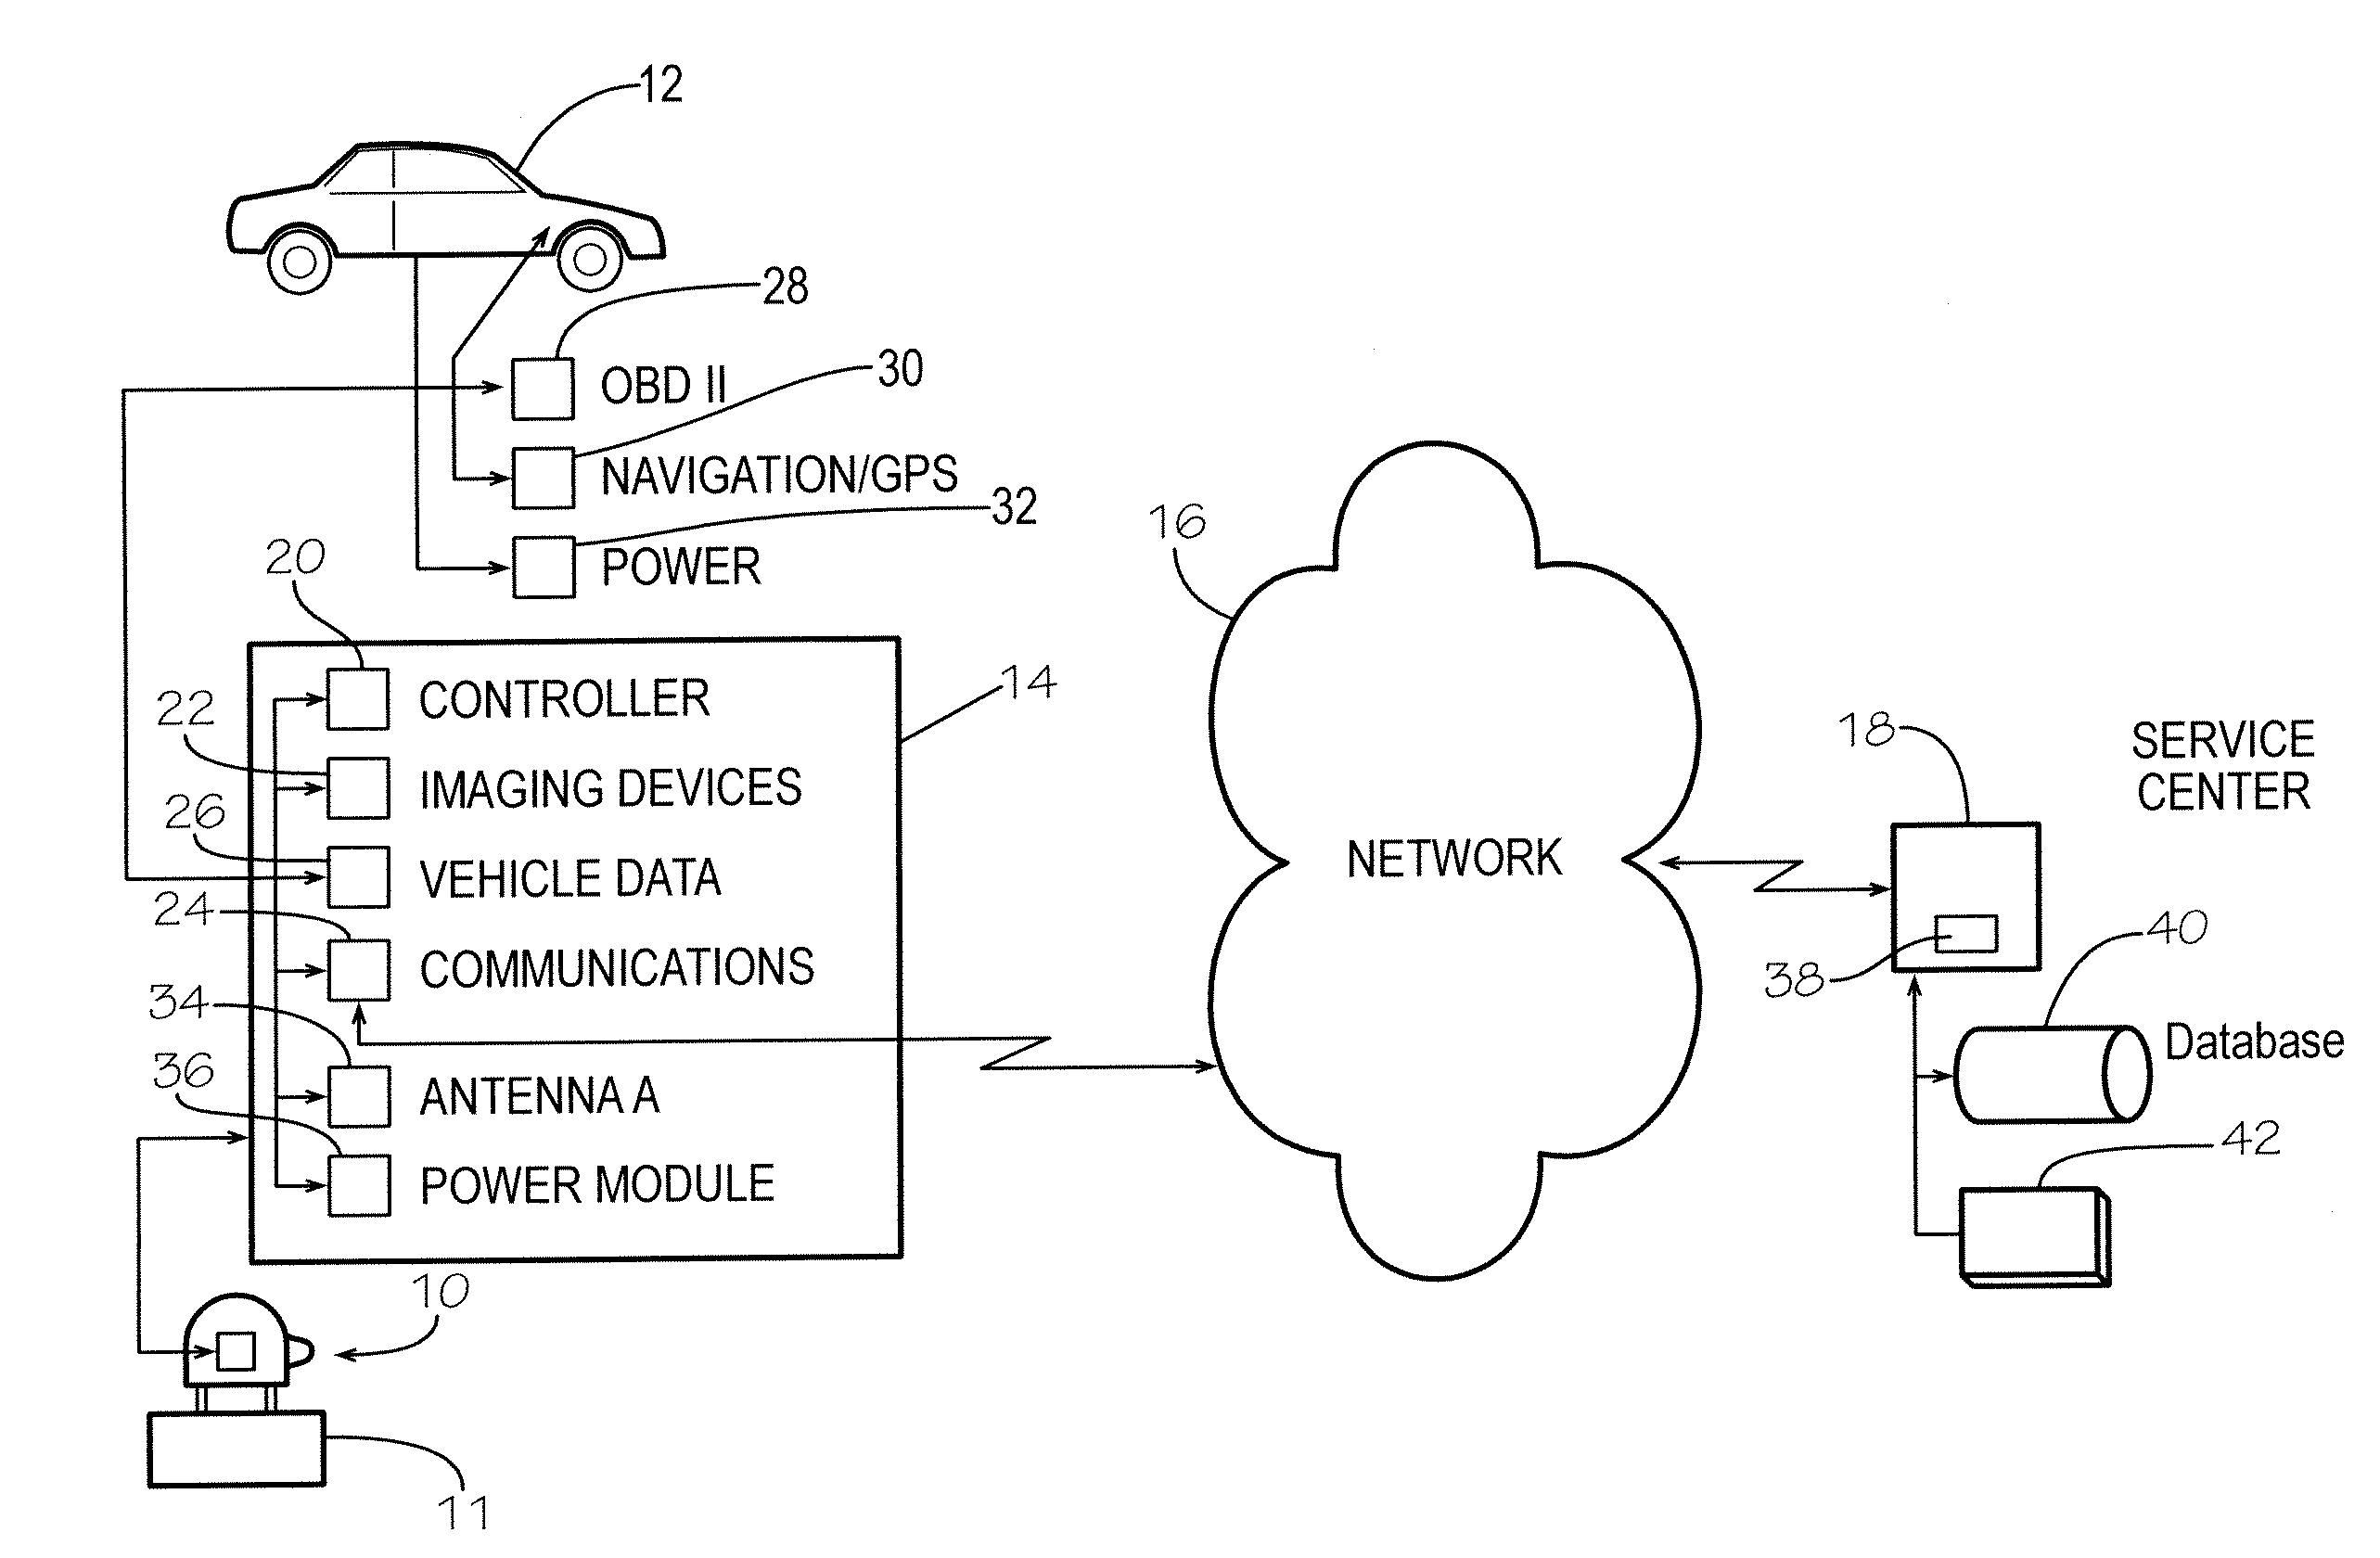
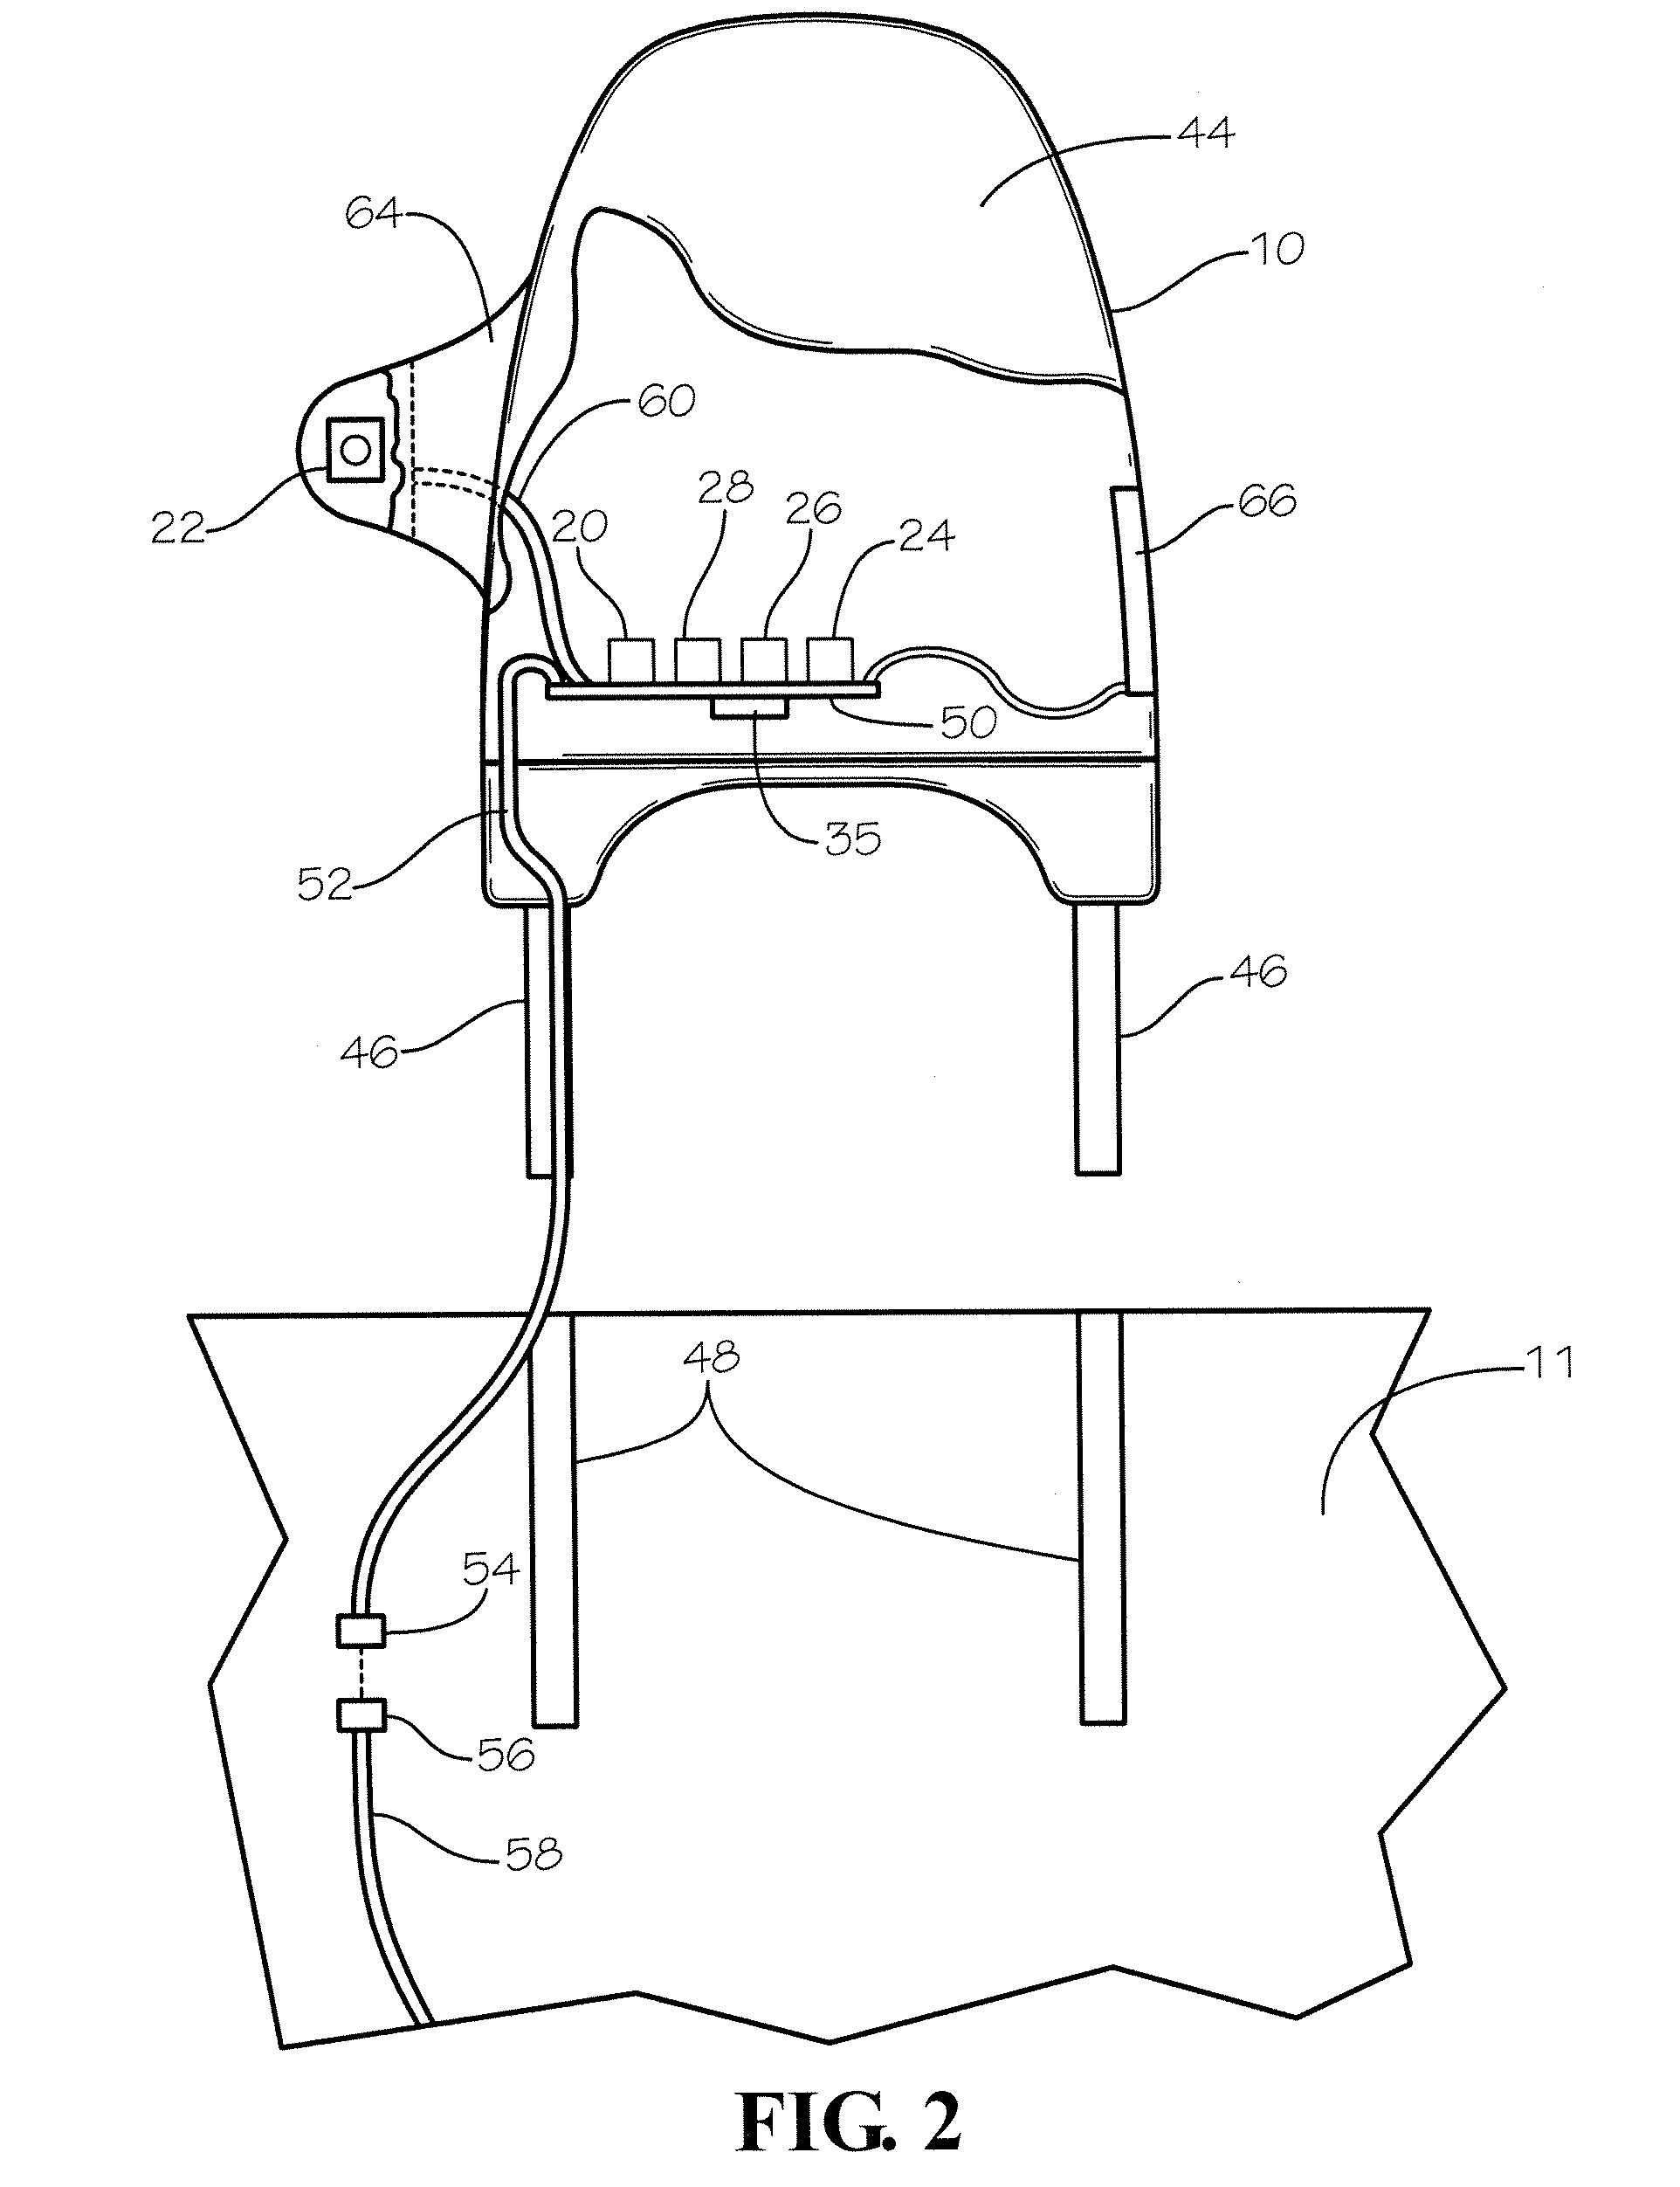
A motor vehicle usage tracking system for monitoring, evaluating, and reporting on operations of motor vehicles each having a modular connected headrest with an imaging device for imaging in a viewpoint from a driver's seating position and communicating with a data bus in the motor vehicle for the operational data correlated with the imaging and communicated to the servicer having an analyzer configure for evaluating and reporting on motor vehicle operations. An aftermarket sleeve is disclosed for retro-fit installation of the motor vehicle tracking device.
Owner:MOBILE VIDEO COMPUTING SOLUTIONS LLC
Sensor system processing architecture
InactiveUS20110298916A1Reduce in quantityReduce cablesImage enhancementImage analysisComputer graphics (images)Computer vision
A system for imaging an area using a plurality of non-contact measurement optical sensors comprises a plurality of substantially identical sensors that detect the presence of a connected network of like sensors, accept the assignment of the role of a managing sensor or a support sensor and individually image a portion of said area. Each sensor may also individually derive image information from its image. The images or image information from each of the plurality of sensors are delivered to the managing sensor which combines them with its own image or image information and that acts as the exclusive client server for delivering the combined image or combined image information to the client.


Owner:LMI TECH
Data transmission method and device
InactiveUS20060215671A1Simple and economicalSlow exchangeDigital data processing detailsTime-division multiplexData transmissionSerial transfer
The invention concerns a data transmission method, and its implementing device, in an integrated closed system of computers, such as, for example, in an aerial or land vehicle, comprising a step which consists in transmitting point-to-point data between two transmission nodes, for example via a wire system, each node having one or more channels enabling each transmission with a single node, a step which consists in converting data for transmission thereof, for example, in series. The invention is characterized in that it does not comprise any step of physical or logical control for authorizing and / or validating the transmitted data so that any data reception at a node is unconditionally followed by a retransmission, that is the control of the dataflows is implicitly determined by the cabled topology used.
Owner:ORTAIS PAUL
Virtual reality system and wireless realization method thereof
ActiveCN106200981ALess restraintImprove experienceInput/output for user-computer interactionGraph readingMicrocontrollerE communication
The invention discloses a virtual reality system and a wireless realization method thereof. The system comprises a host, a virtual reality helmet which is connected with the host in a communication mode and is used for displaying virtual reality scene images in real time, multiple wireless handle controllers and multiple wireless camera devices which are installed around the space of the virtual reality helmet; the virtual reality helmet comprises a microcontroller, a first wireless chip and a second wireless chip; the first wireless chip is connected with the wireless camera devices to obtain position tracking information and send the information to the microcontroller; the second wireless chip is connected with the wireless handle controllers to obtain control command information and send the information to the microcontroller; the microcontroller sends the received information to the host and sends interaction instructions of the host to the wireless handle controllers through the second wireless chip; position tracking data and control command information are wirelessly transmitted to reduce constraint of cables on users; therefore, users can flexibly apply the virtual reality system and avoid treading wires so that user experience is increased.


Owner:BEIJING PICO TECH
Nuclear magnetic resonance (NMR) probe
InactiveUS7560932B2Reduced insertion lossHigh sensitivityMagnetic measurementsElectric/magnetic detectionNMR - Nuclear magnetic resonanceControl signal
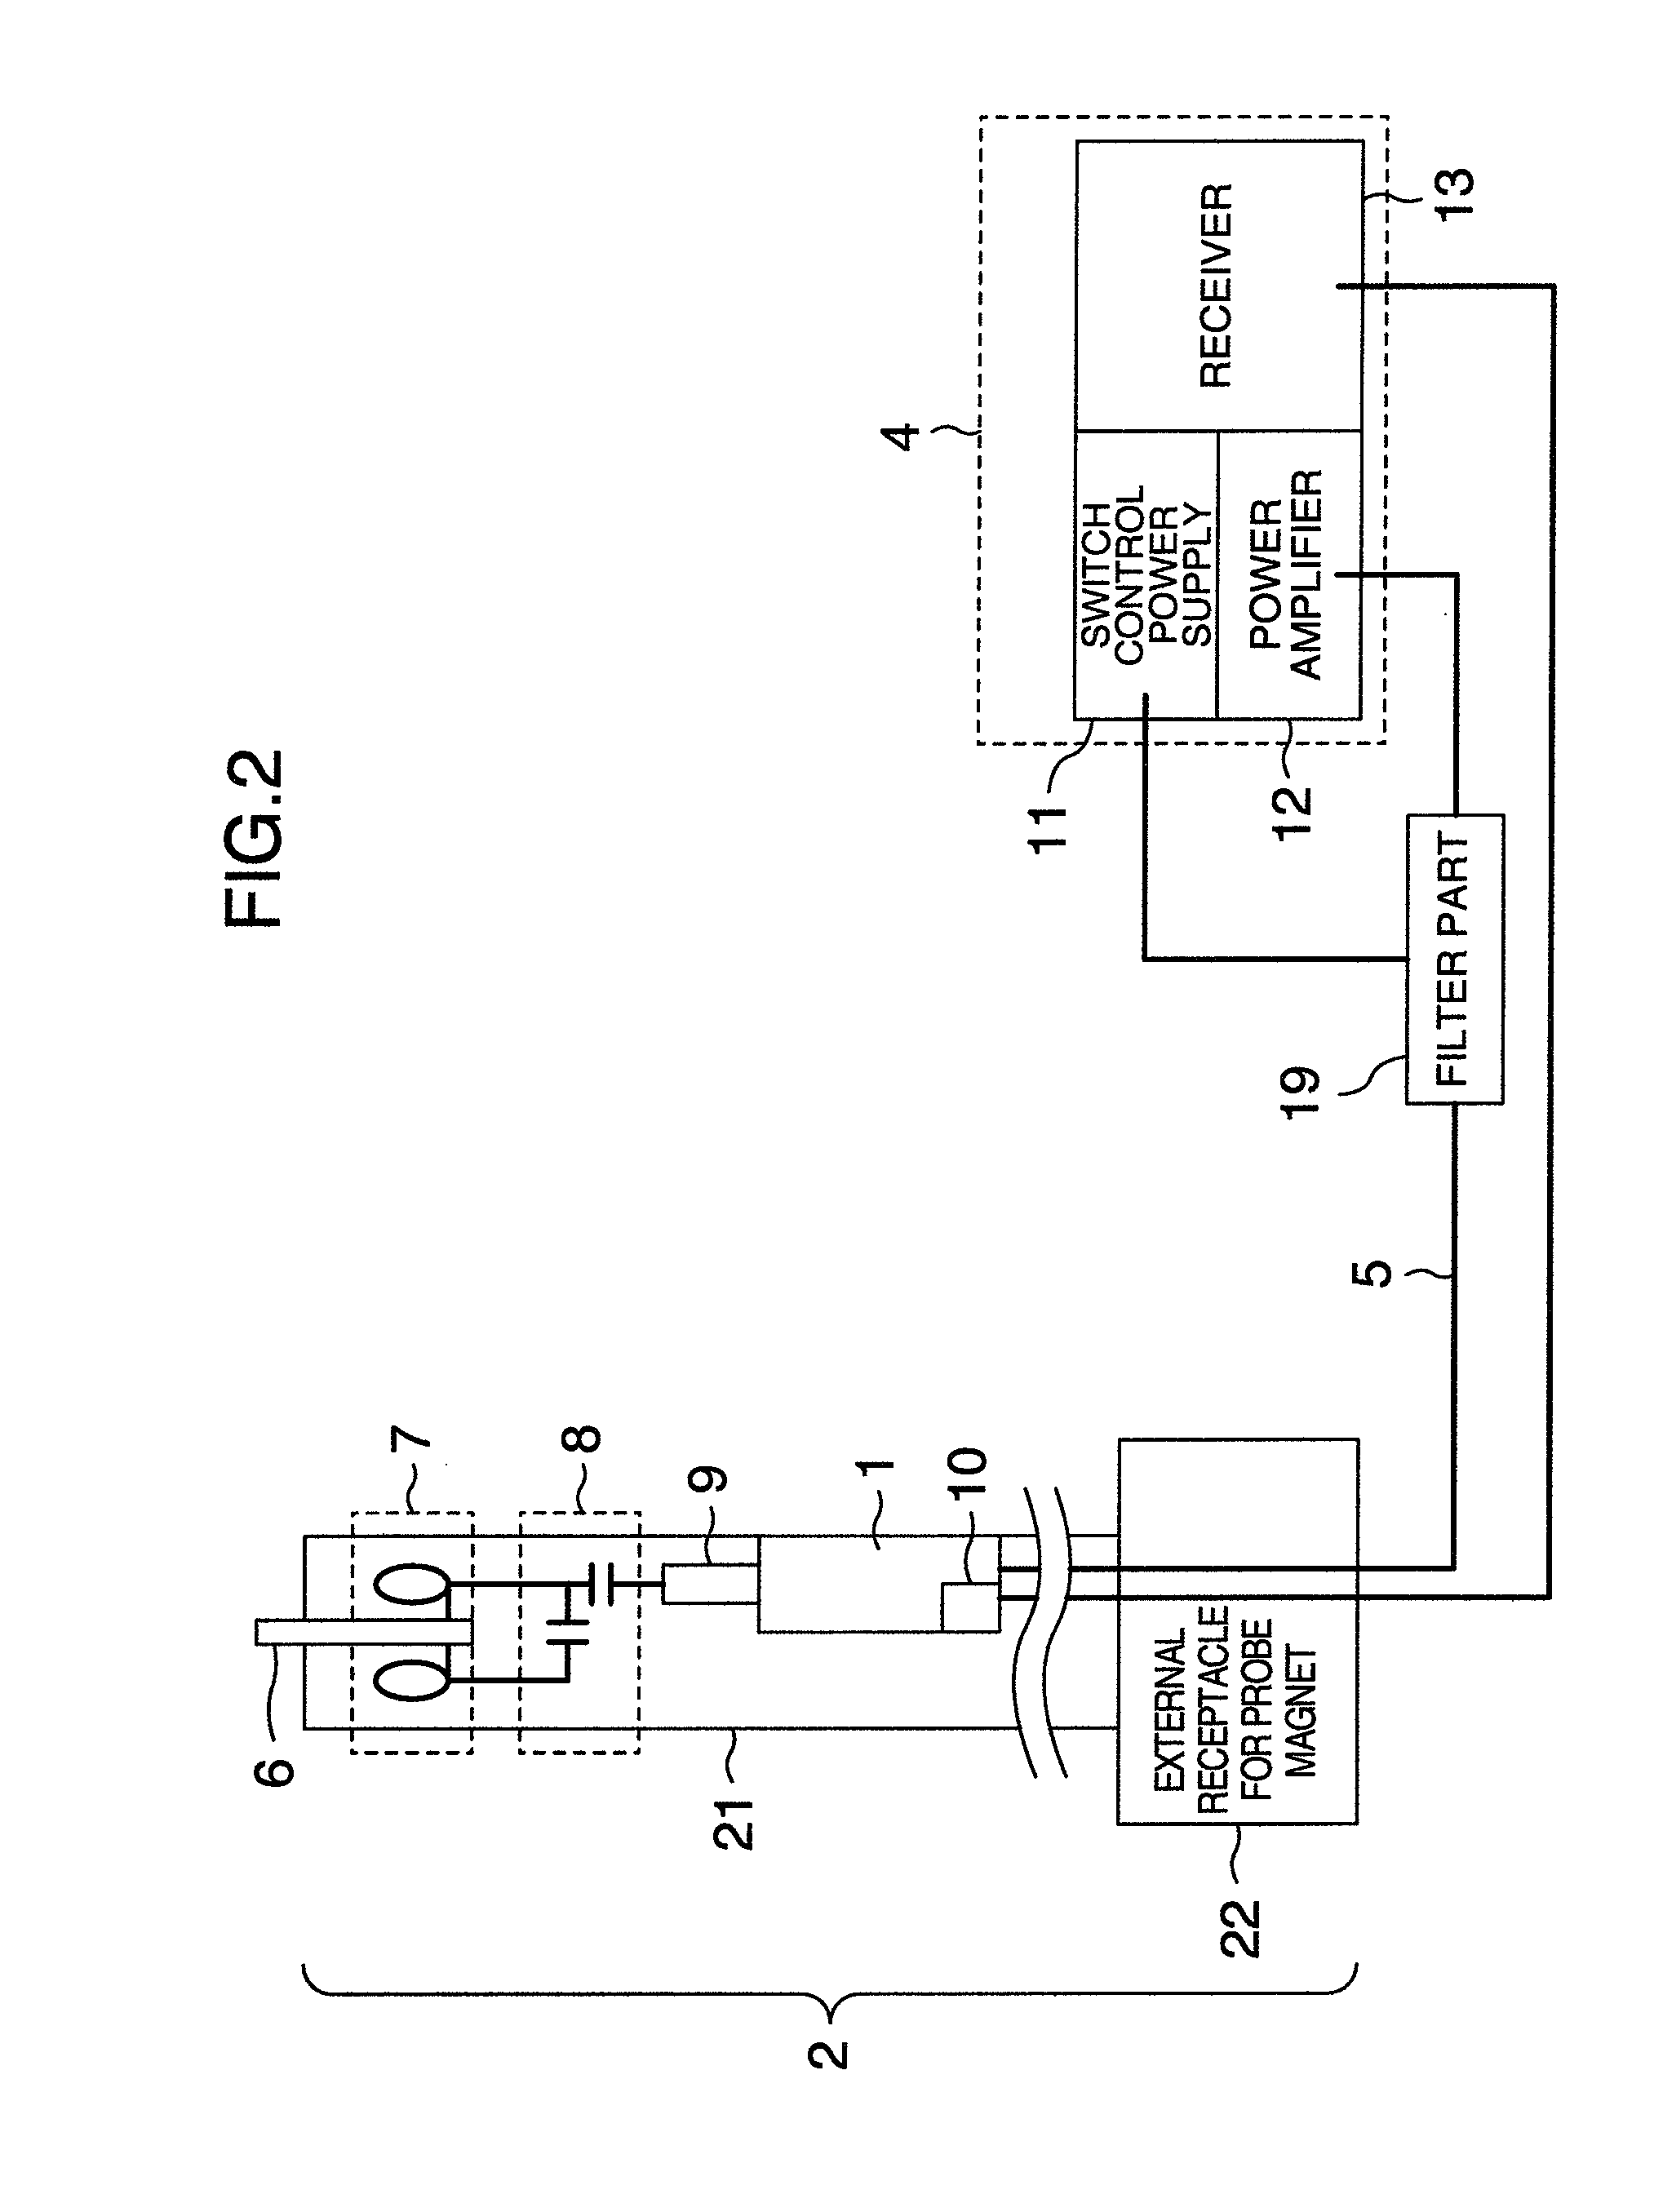
There is provided a nuclear magnetic resonance probe in which the loss caused by a high frequency cable between a probe coil and a preamplifier is reduced and the sensitivity of an NMR signal is improved. A changeover switch for NMR probe is divided into a switch part including switch elements and a filter part for filtering a switch control signal and an RF transmission signal. The switch part is disposed in a probe body inserted in a magnet of the probe. The filter part is disposed near a measurement apparatus located outside the probe. As for the switch part, a section structure of thickness and width is reduced in conformity with a narrow and slender shape of the probe body. The length of a high frequency cable between the probe coil and the preamplifier is shortened remarkably, and consequently the loss can be reduced.


Owner:HITACHI LTD
Marine cabin lighting control system
InactiveCN110868772AEasy to manageHighly integratedElectrical apparatusControl engineeringControl circuit
The invention discloses a marine cabin lighting control system. The system comprises a display control unit, a cabin light sub-controller, a lighting scene controller, a time adaptive controller, a brightness, color temperature and color regulator, a dimming driving control circuit, an LED module and a cabin light centralized controller. Cabin lighting light can be set according to the requirements of the environment and personnel activity scenes, and synchronous matching change of the light along with the physiological rhythm of the human body is achieved in a specific control mode. The LED module is driven by the lighting control system to realize the functions of lighting, picture display and video display of the cabin, state monitoring of lighting lines and lamp points of the marine cabin is achieved through the control system, and modular expansion and centralized monitoring can be conducted.


Owner:CHINA SHIP DEV & DESIGN CENT
Floating roof monitoring with laser distance measurement
ActiveUS20160229627A1Improve securityLow costLarge containersMachines/enginesLaser rangingLevel sensor
A floating roof monitoring system and method. One or more sensors can be disposed atop a liquid storage tank having a floating roof covering liquid stored in the liquid storage tank. Each laser sensor measures the distance between the sensor and the floating roof. One or more liquid level gauges can be deployed, which measure a liquid position of the liquid stored in the liquid storage tank. A computing system communicates electronically with the laser sensor(s) and the liquid level gauge(s) to calculate the difference between the liquid position and the distance between the sensor(s) and the floating roof to determine the exact position of the floating roof and activate an alarm or force a process associated with the liquid storage tank to halt.


Owner:HONEYWELL INT INC
Car wash controller
InactiveUS6871103B2Eliminate wiringWithout usingElectric signal transmission systemsFrequency-division multiplex detailsElectrical devicesElectric power
A car wash controller for receiving input data from a plurality of remote input devices and for controlling the operation of multiple remote output electrical devices. The central controller is coupled to a series of input boards by a communication cable, such as a telephone cable, to receive input data from the input electrical devices. The input boards can be coupled to each other to reduce the amount of wiring within the car wash environment. The central controller is further connected to a series of output relay boards, each of which are connected to a supply of power. The central controller is connected to the output relay boards by a communication cable such that an output command can be sent to each relay board to supply electrical power to the output electrical devices. The relay boards can be coupled to each other to reduce the amount of wiring within the car wash environment.


Owner:DELAWARE CAPITAL FORMATION
Equipment and method for controlling an elevator door
InactiveUS20080236955A1Low costSave spaceBuilding liftsHoisting equipmentsControl systemData transmission
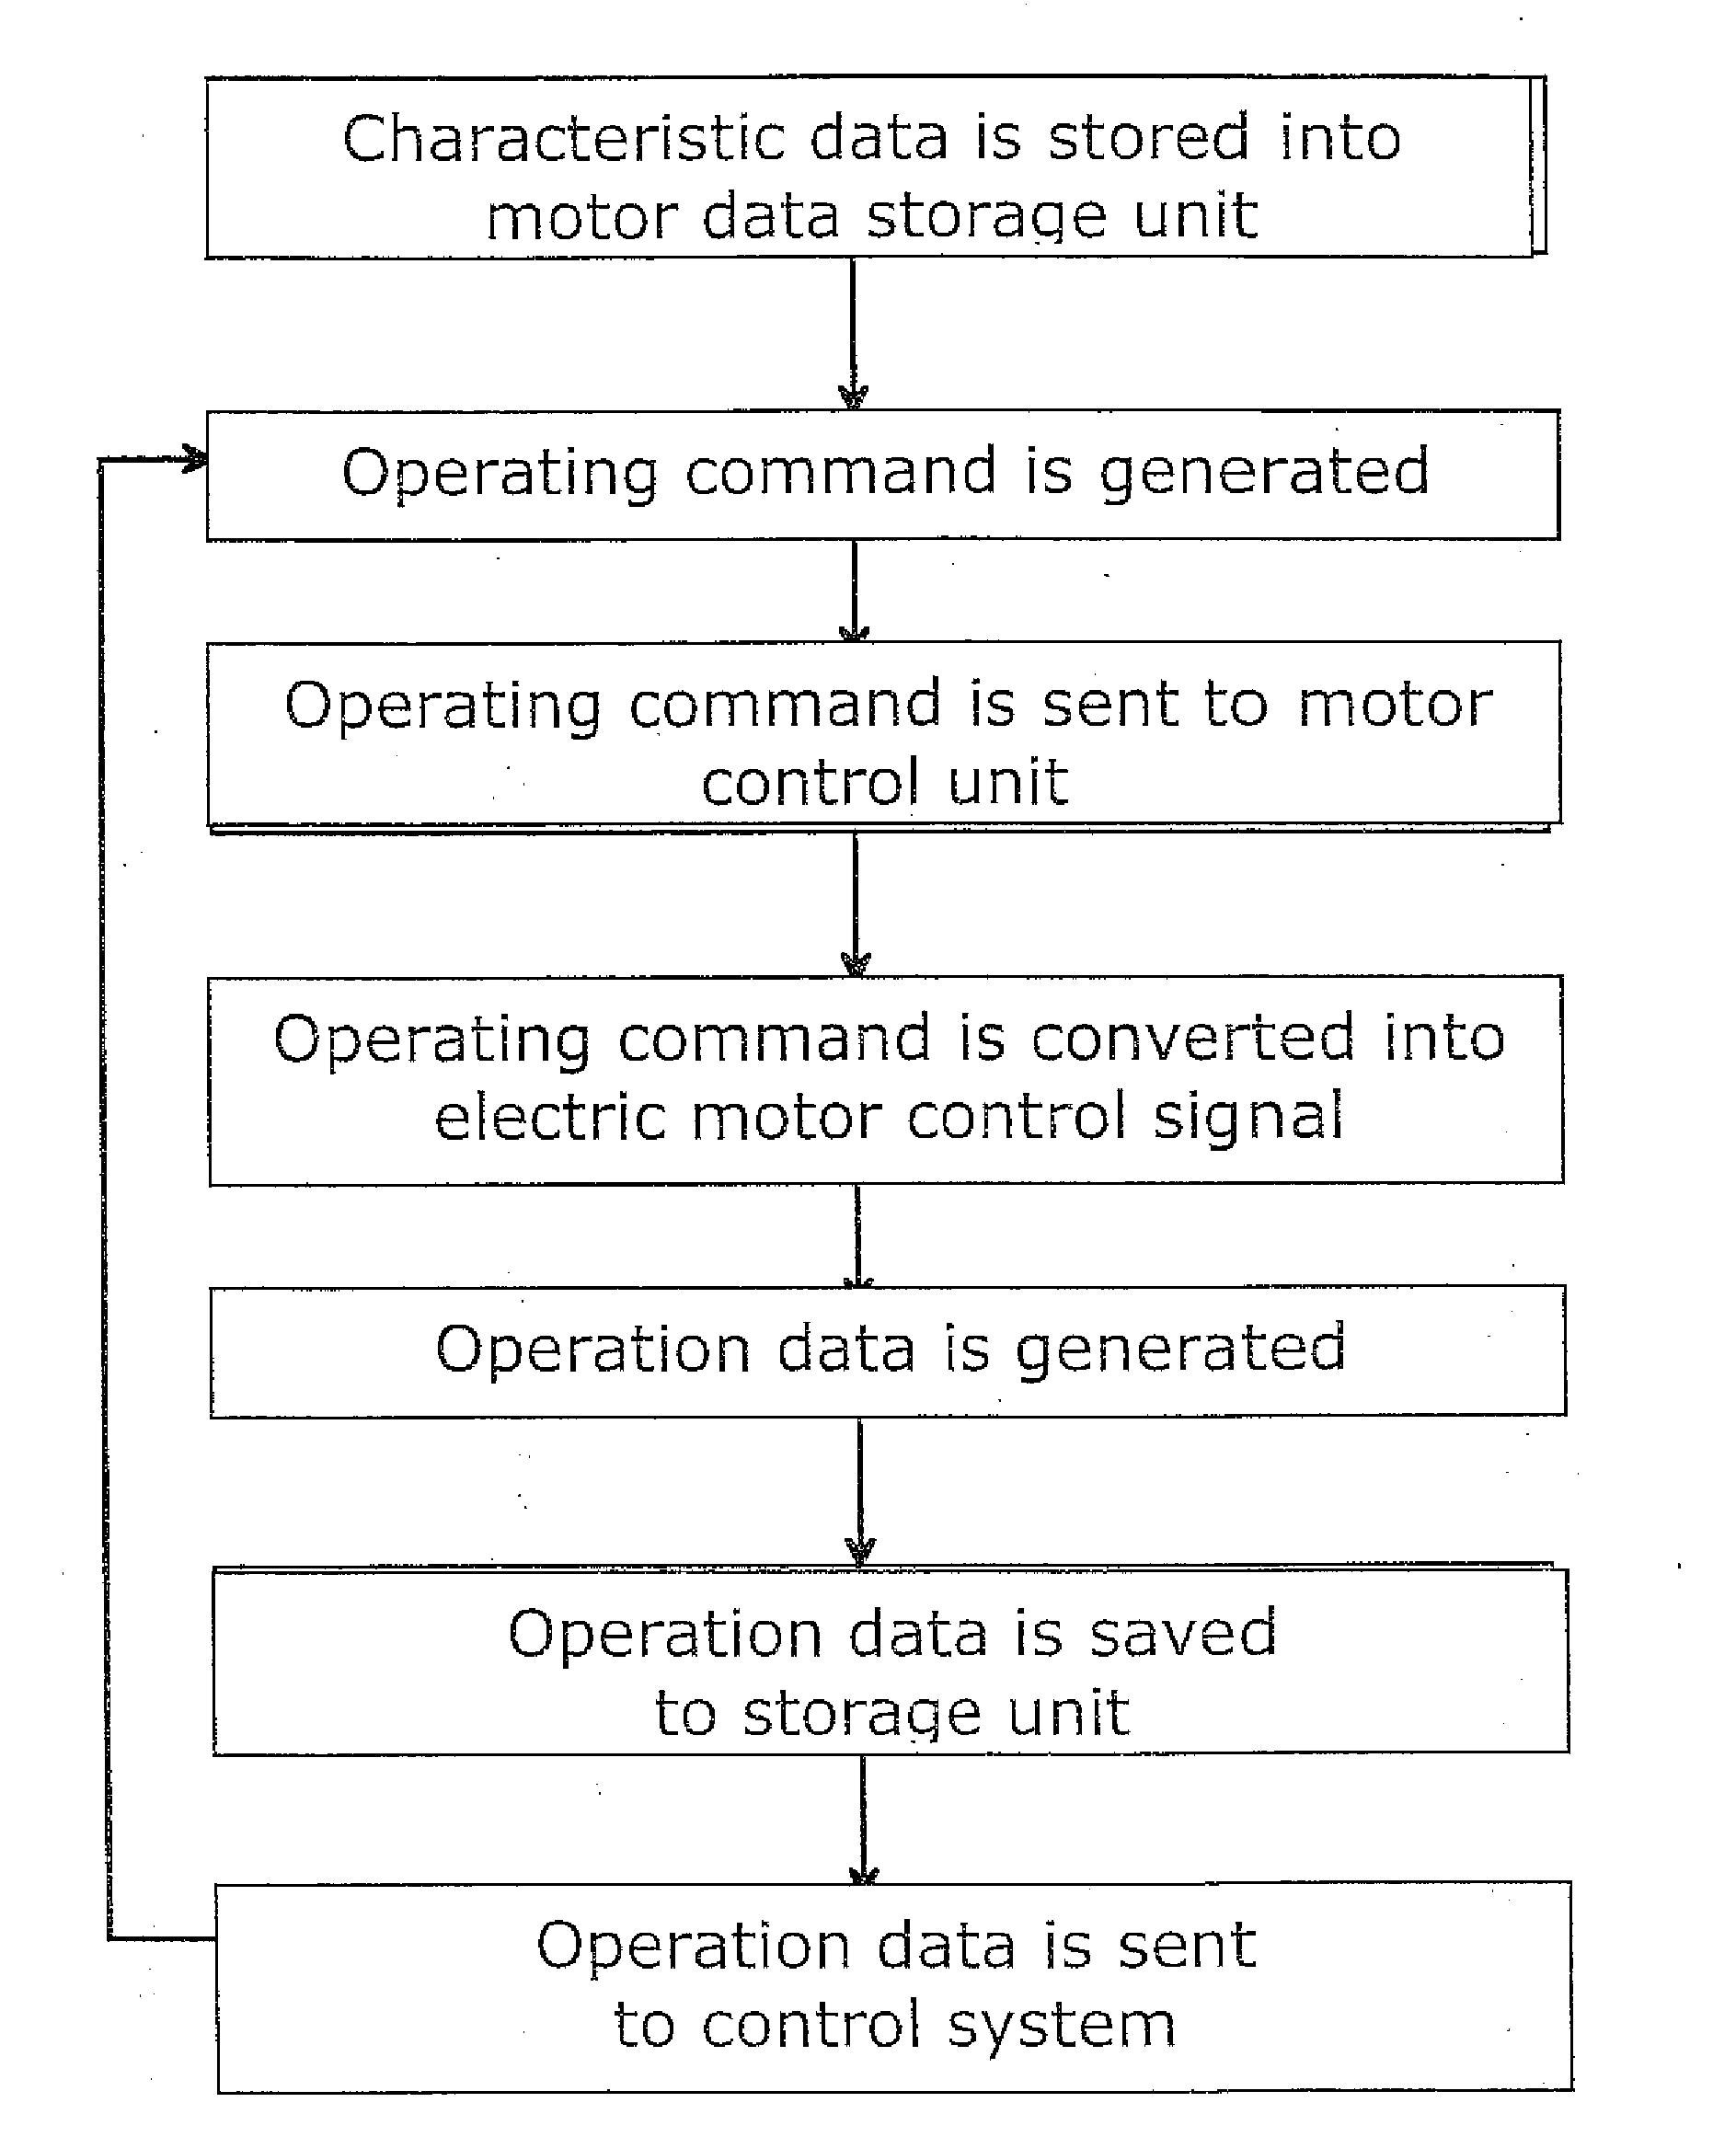
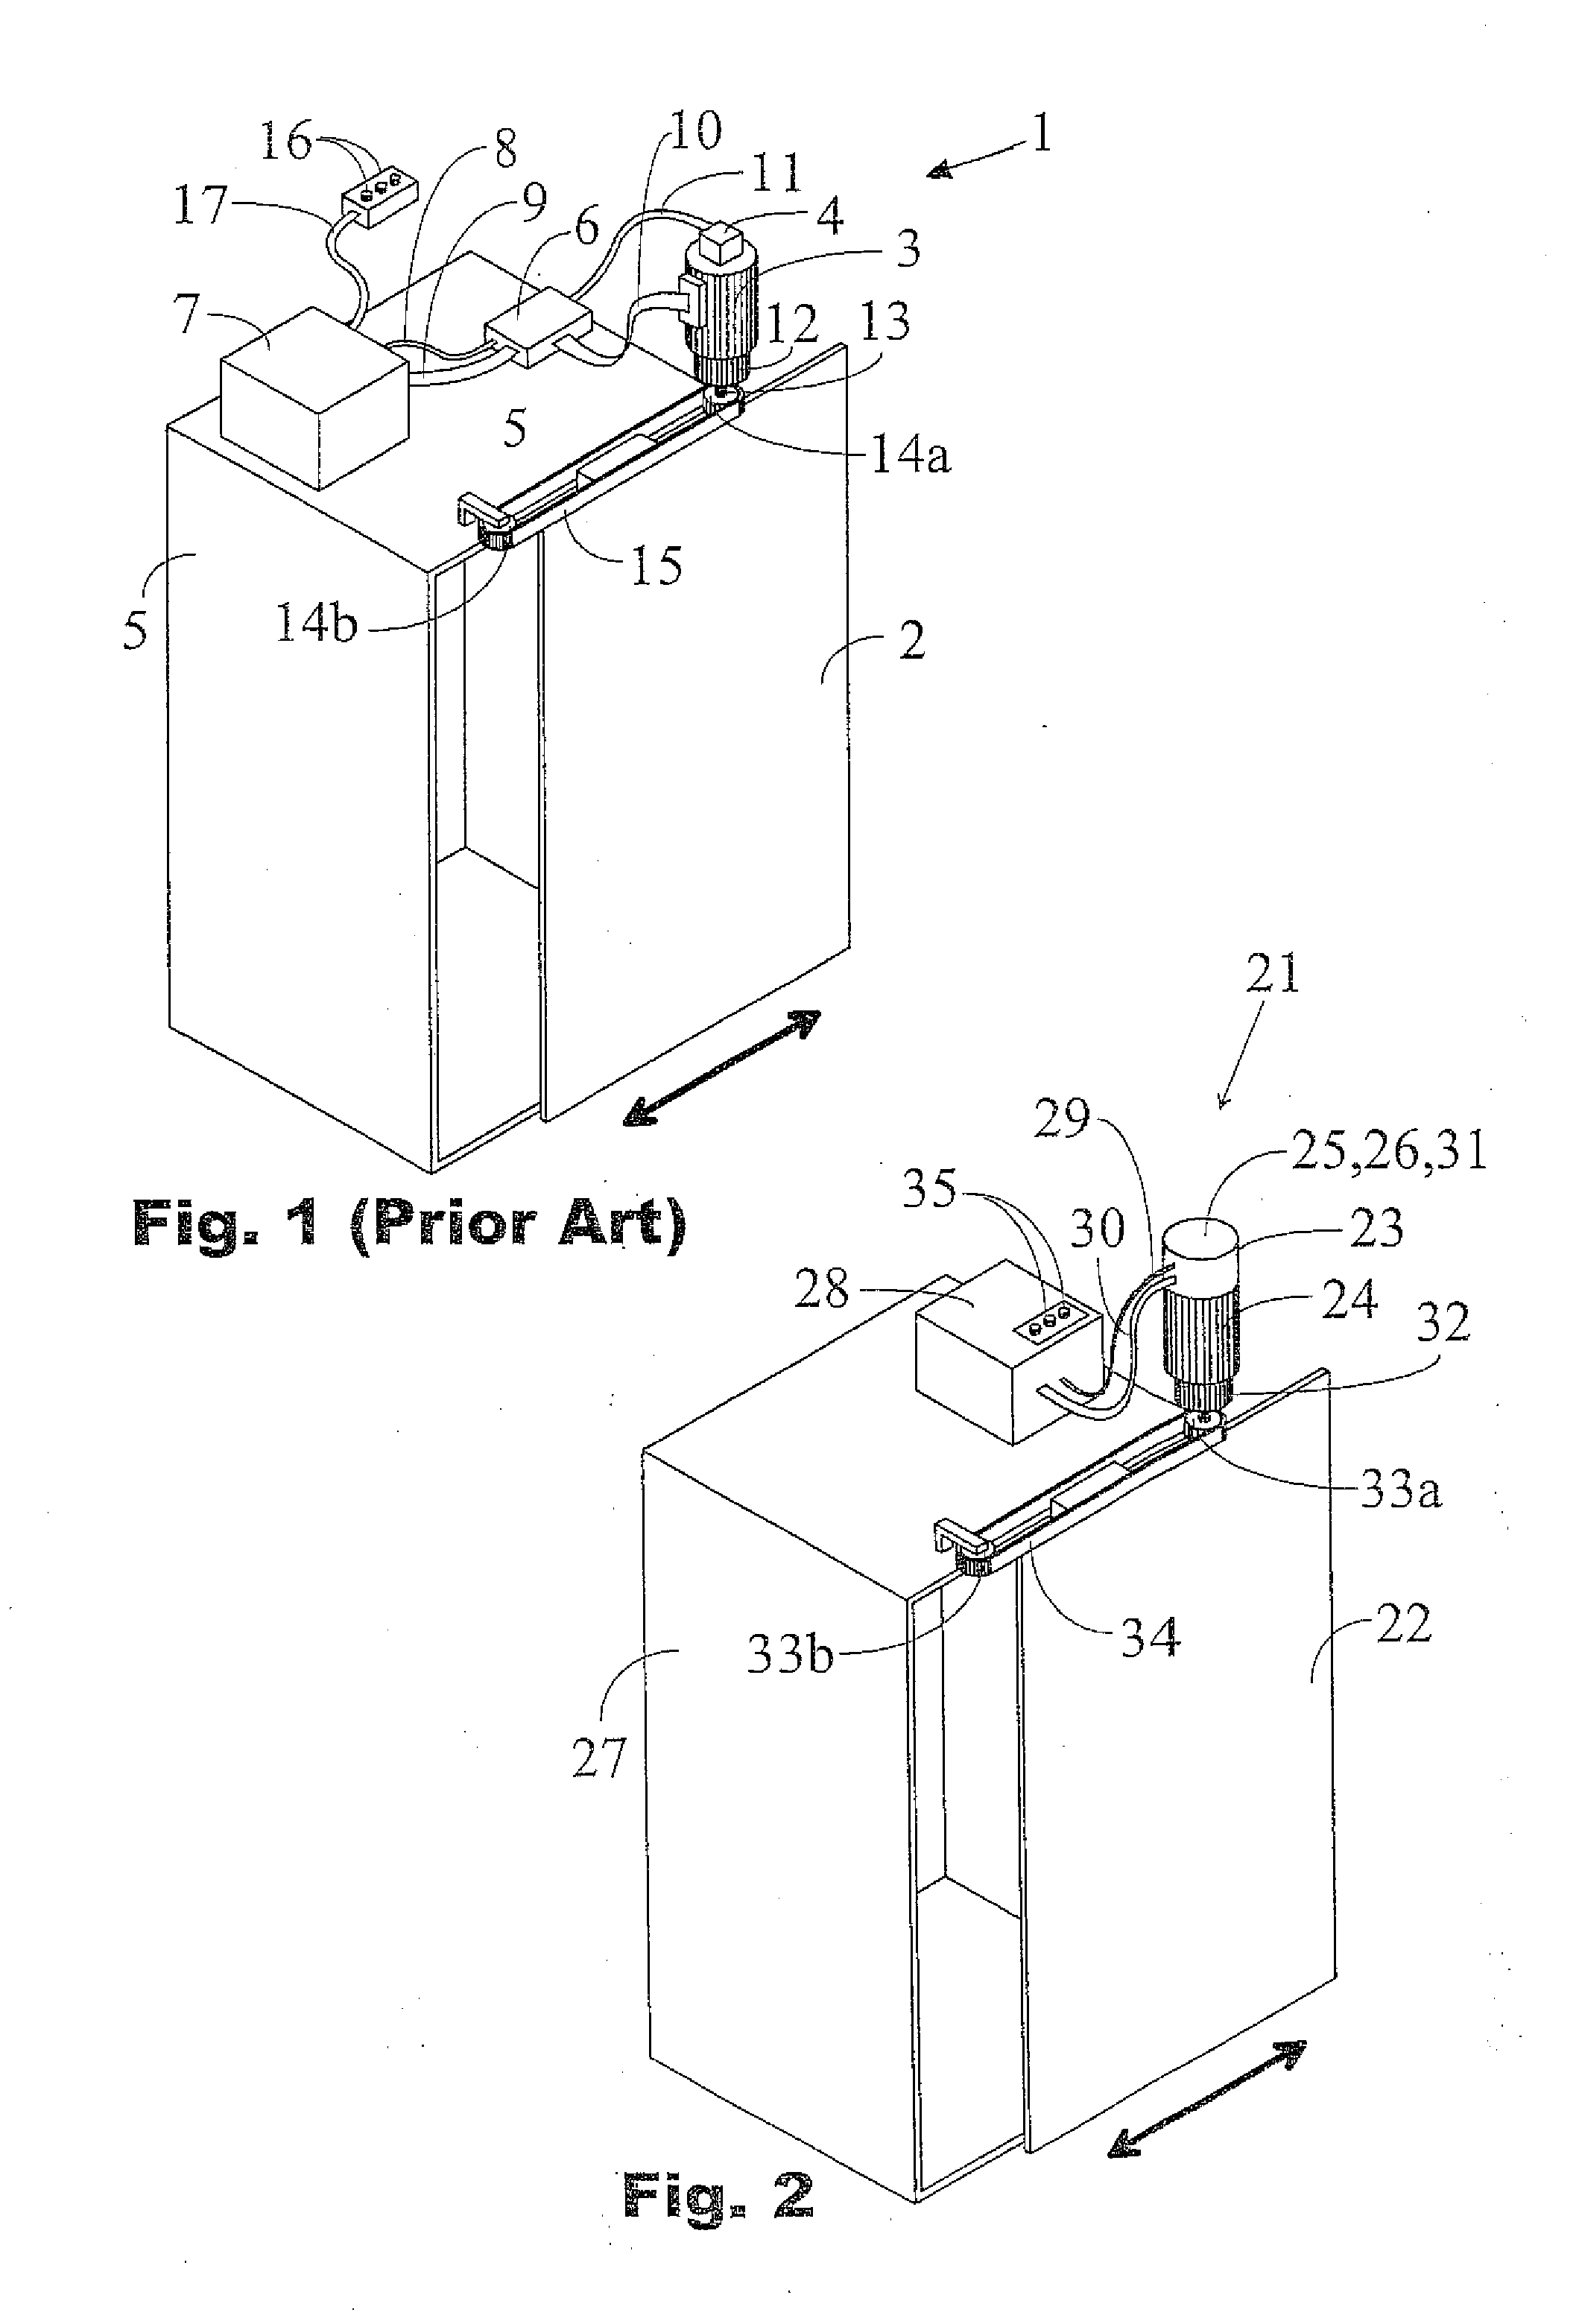
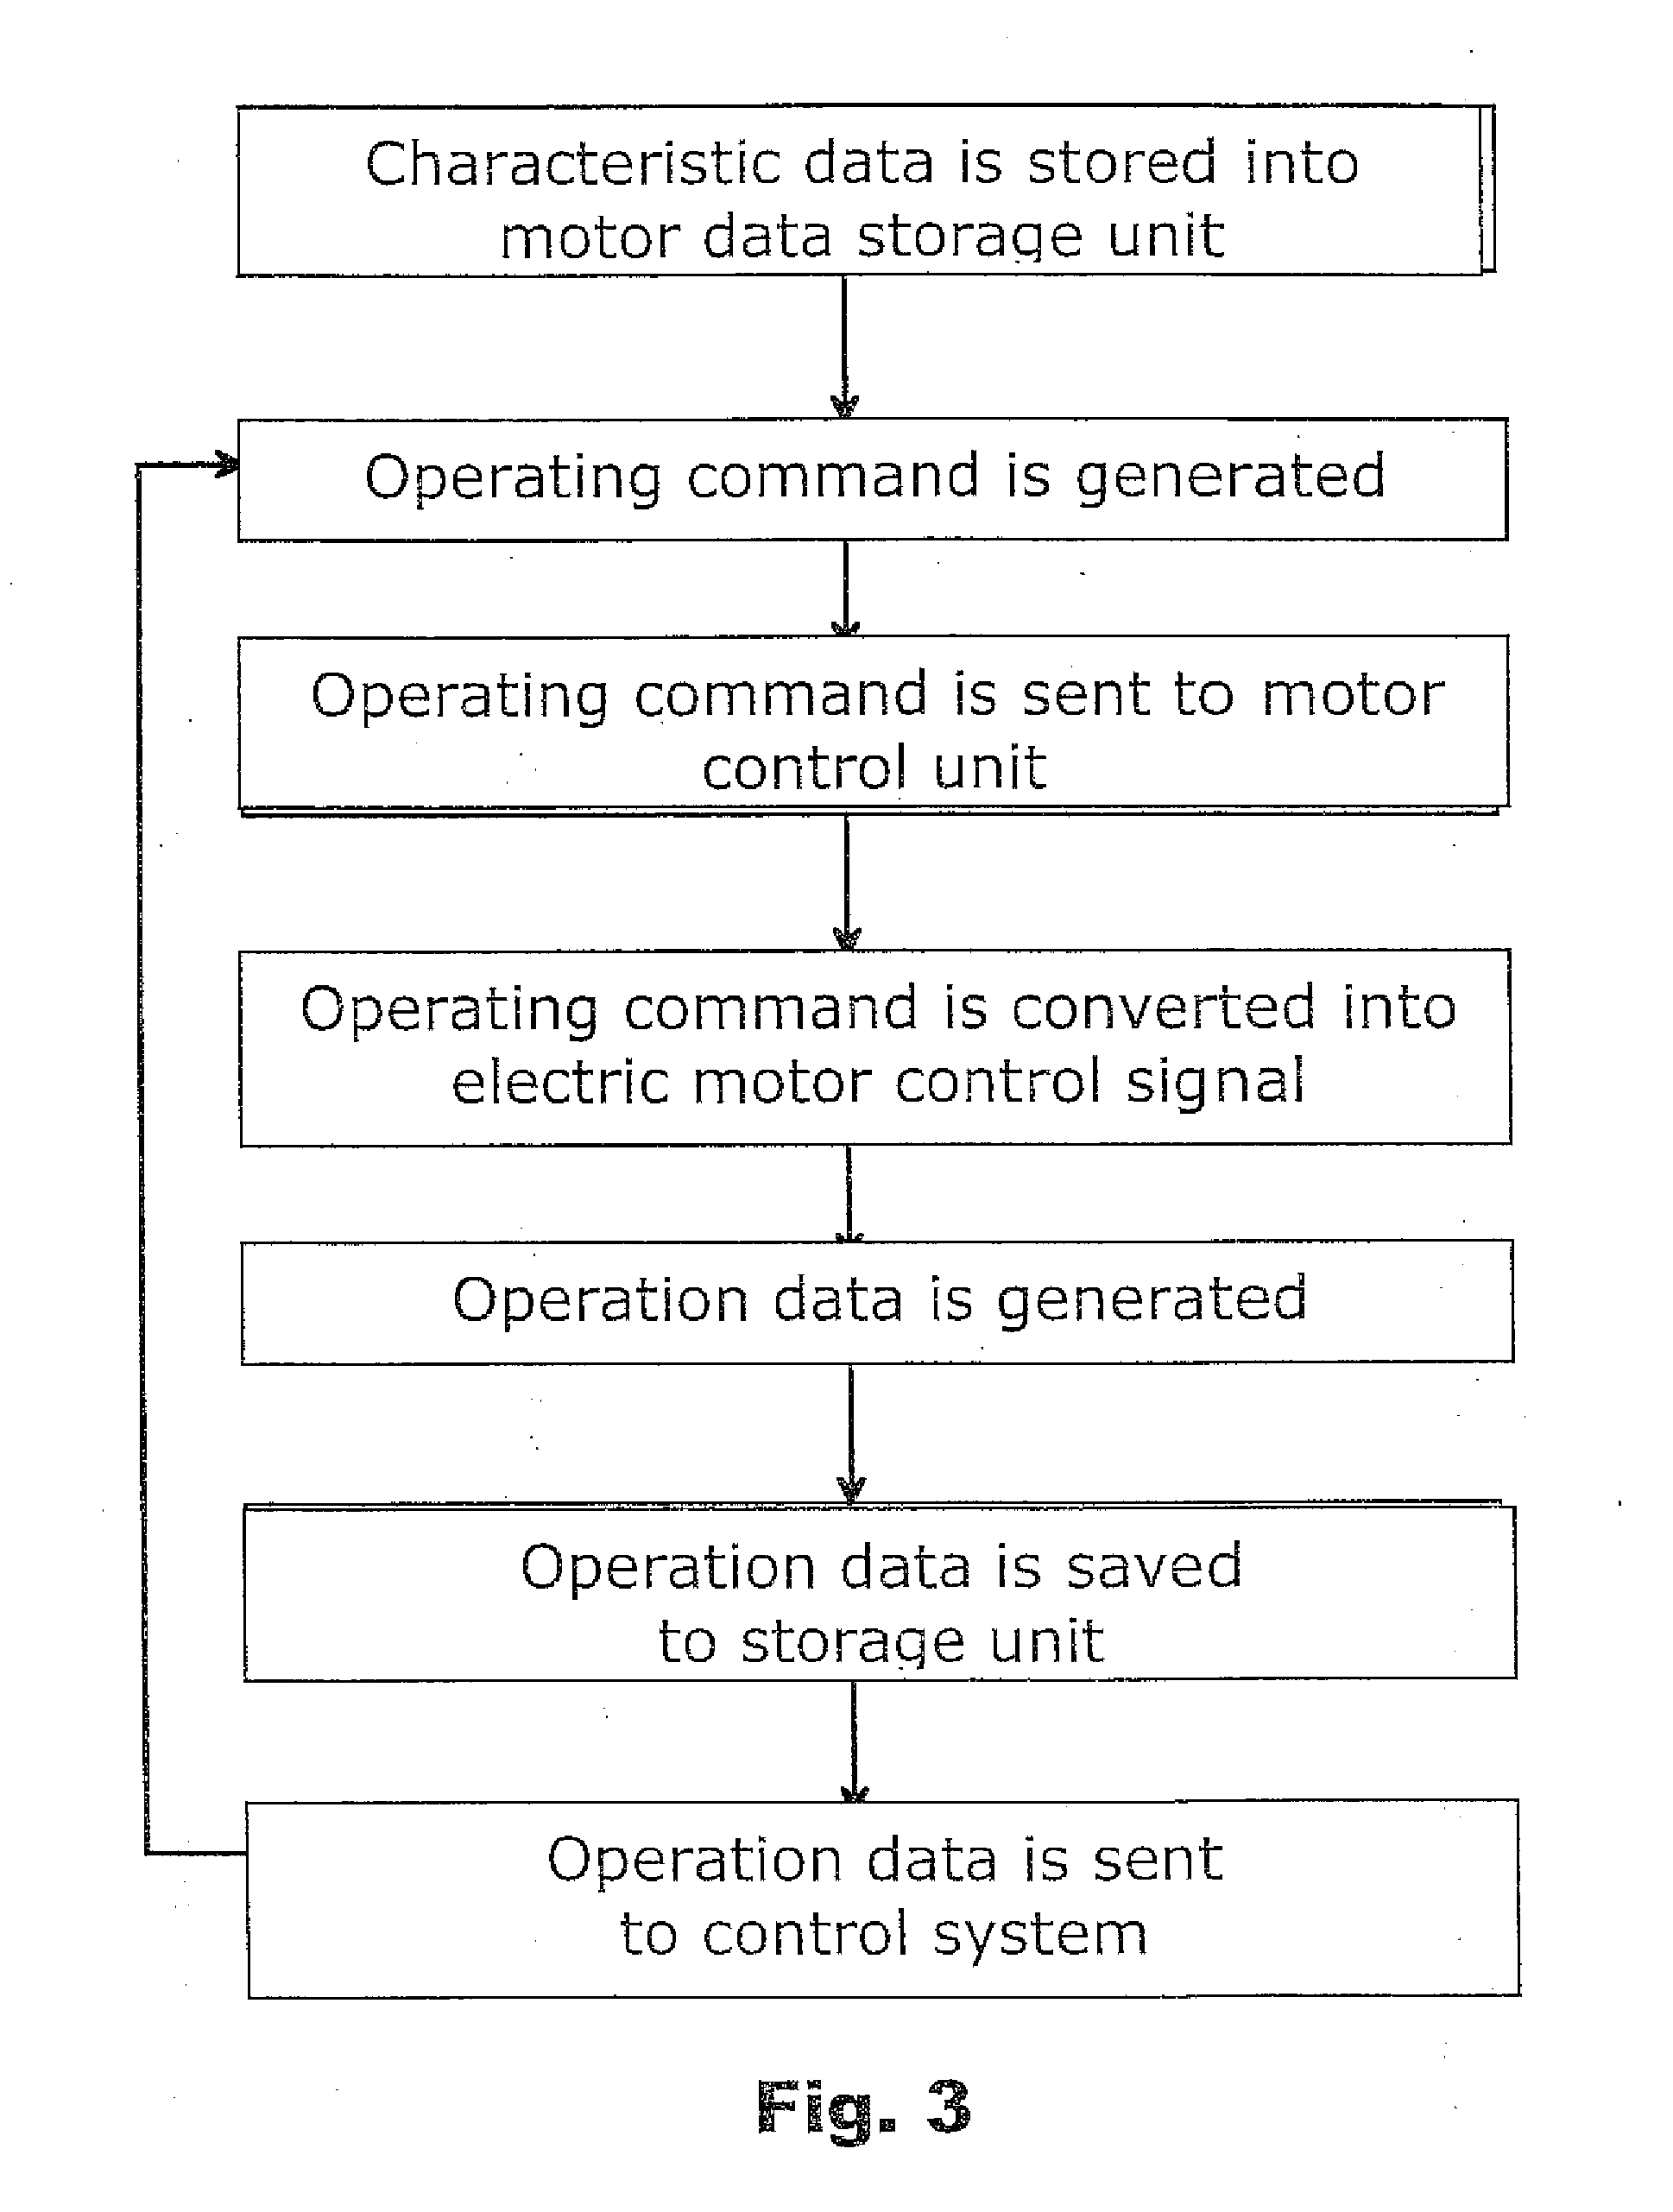
An equipment (21) for controlling an elevator door (22) comprises a motor (24), an encoder (25) connected to the motor and a motor control unit (26), which are integrated into a coherent motor unit (23), an elevator control system (28), power supply means (29) for supplying operating power from the control system to the motor unit, and a data transfer bus (30) for data transfer between the control system and the motor unit. According to the invention, the data transfer bus (30) is bi-directional, and the motor unit (23) comprises a motor data storage unit (31).
Owner:KONE CORP
Sensor system processing architecture
InactiveUS20160171712A1Reduce in quantityReduce cablesTelevision system detailsImage enhancementComputer graphics (images)Computer vision
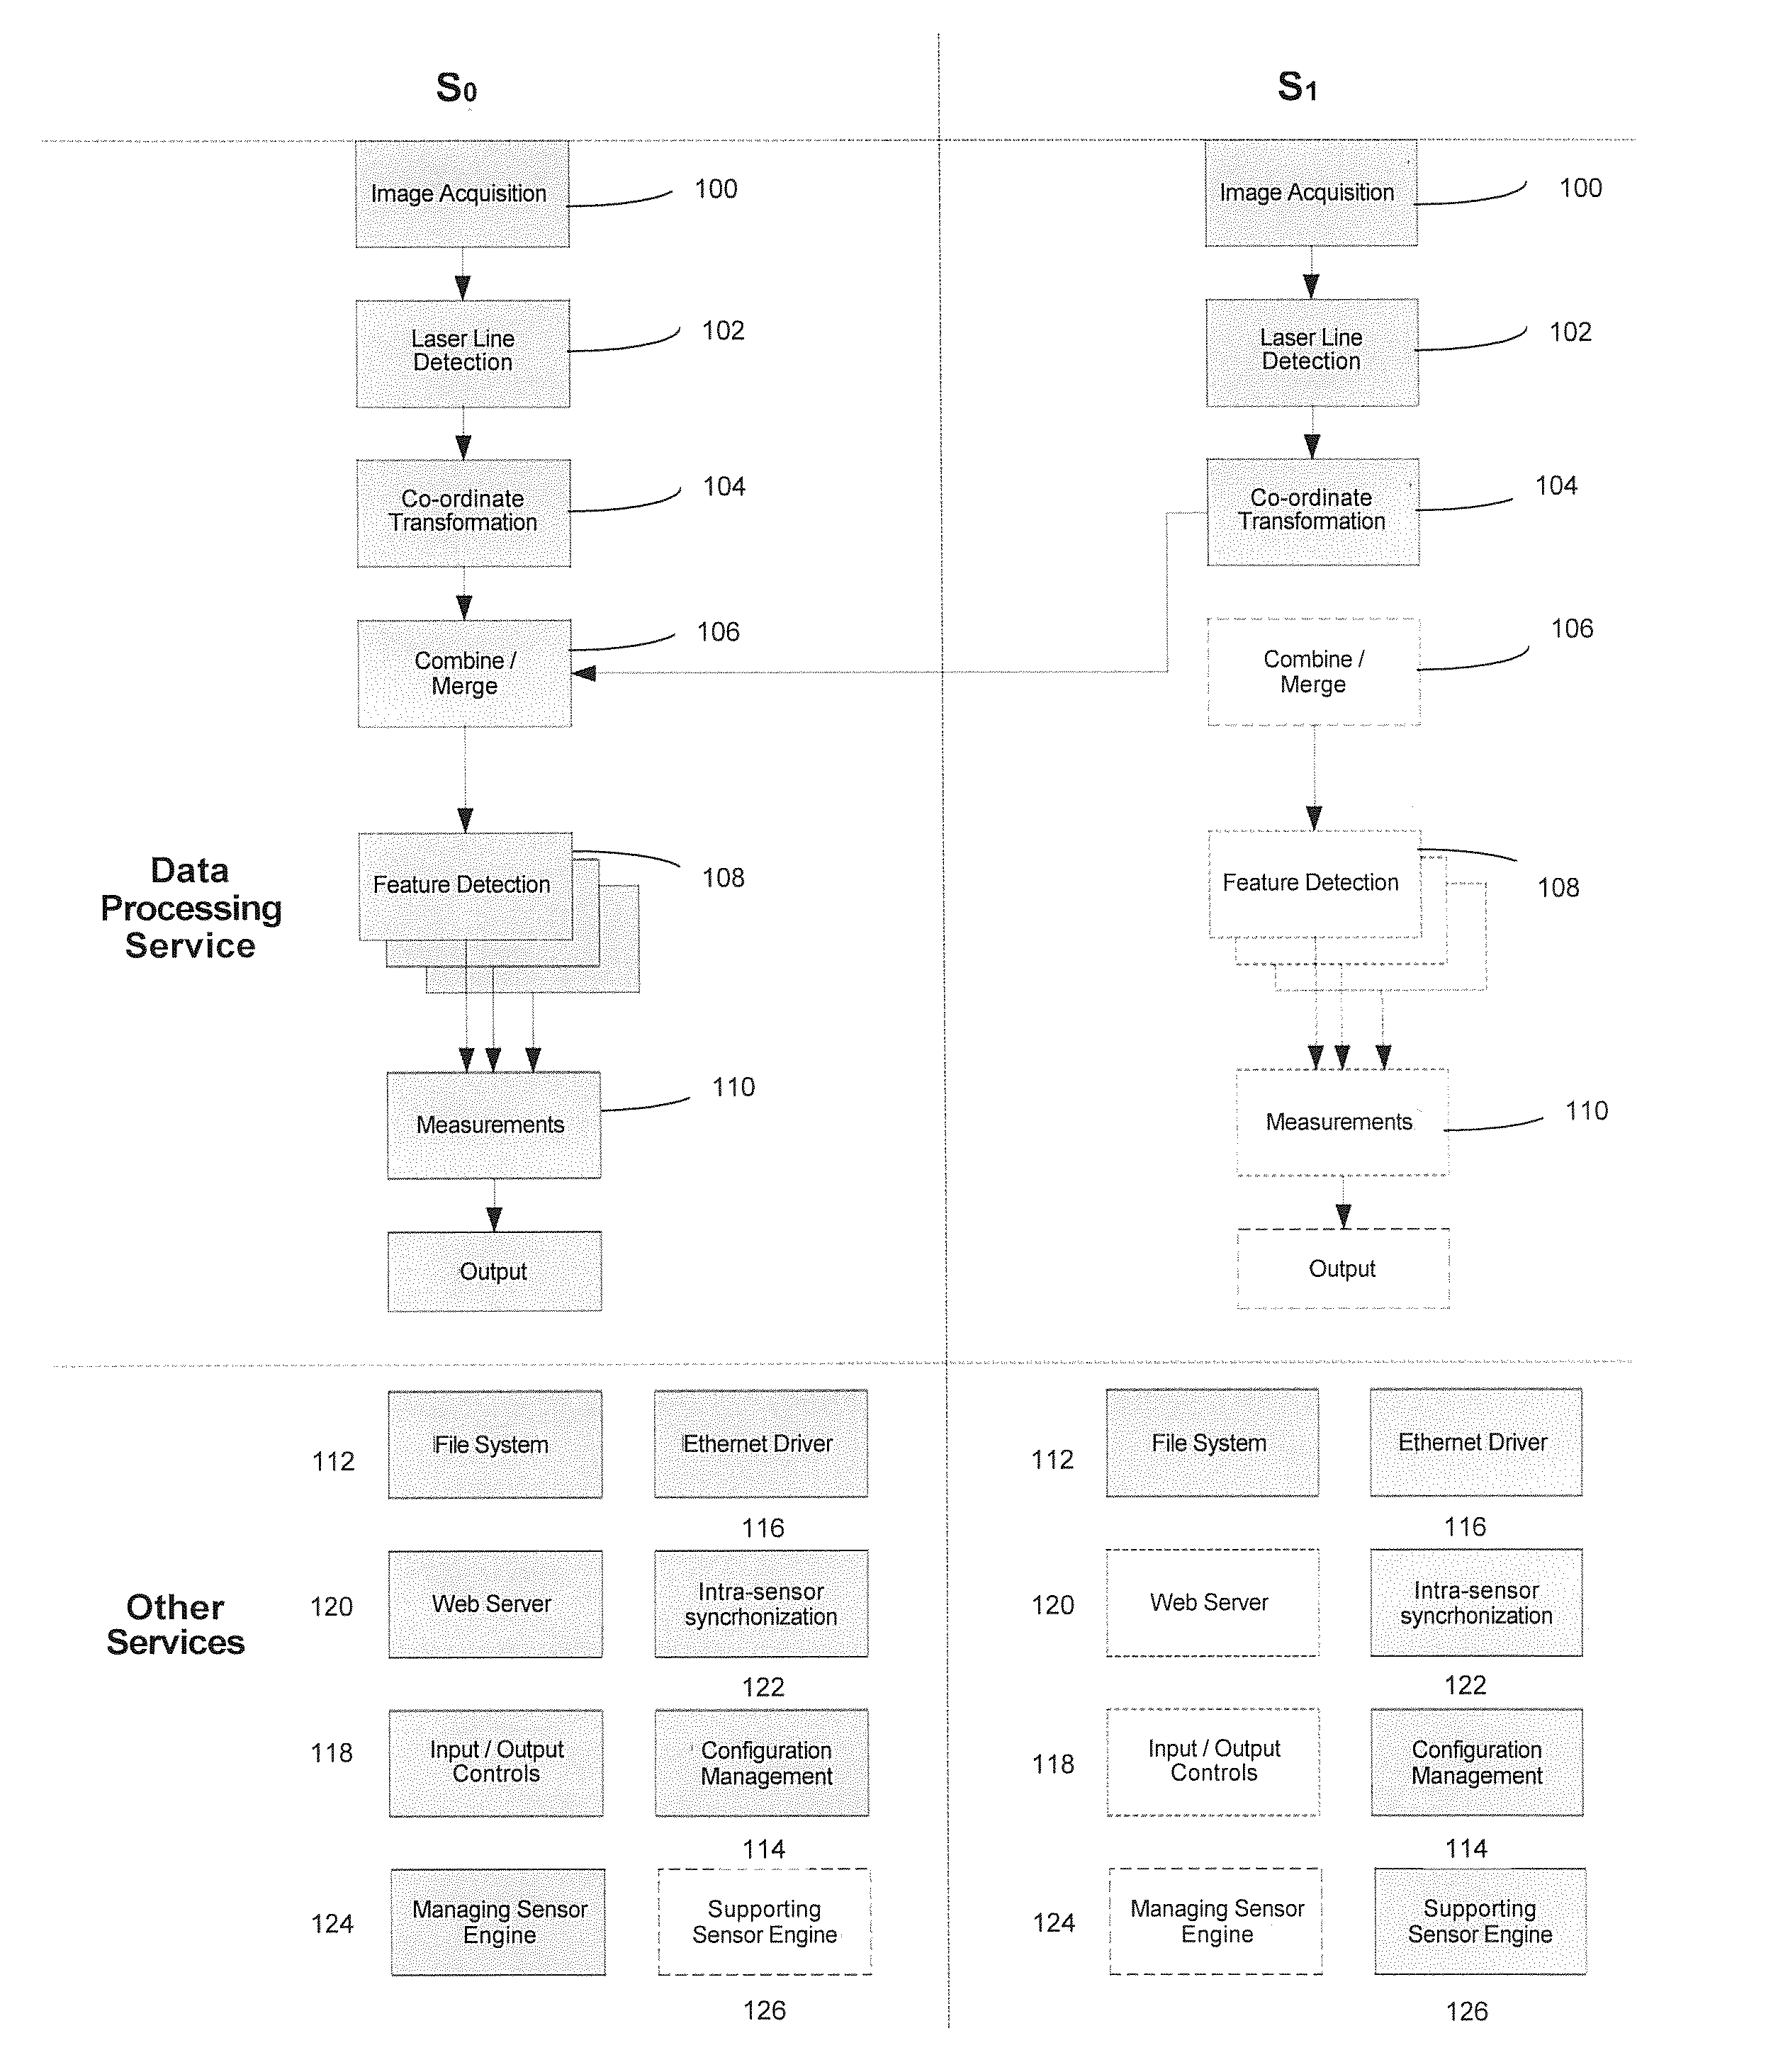
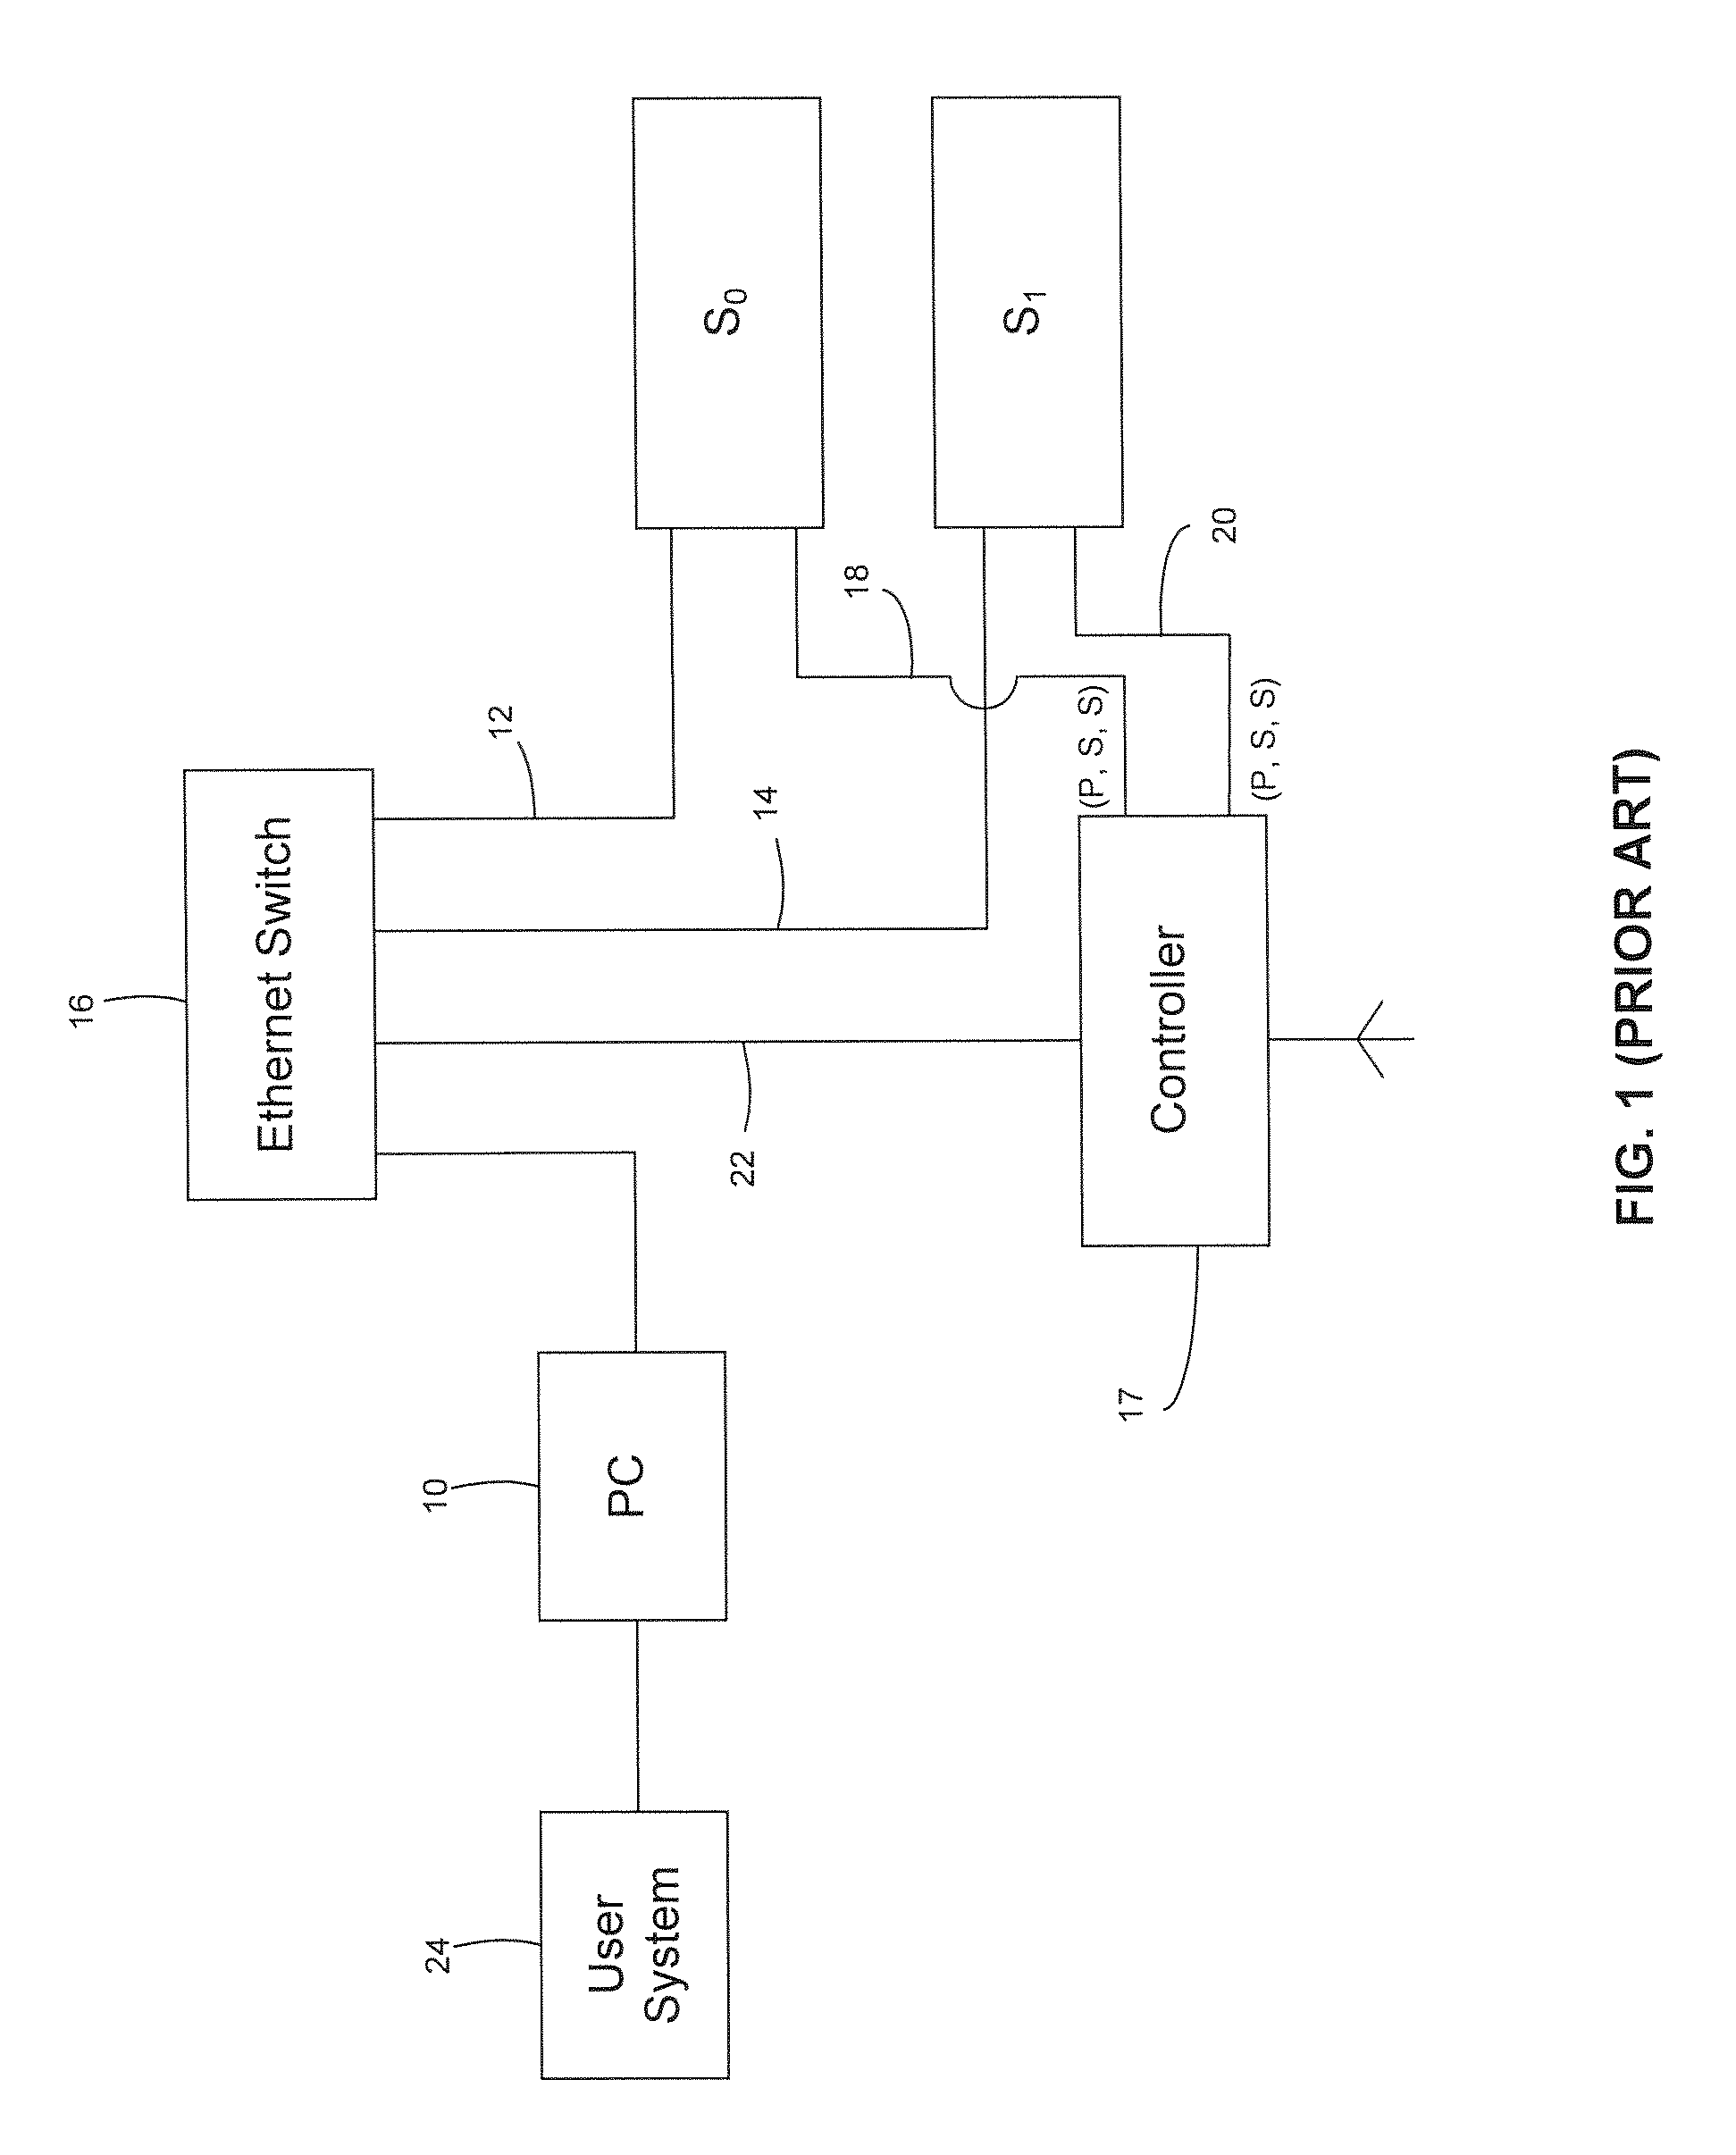
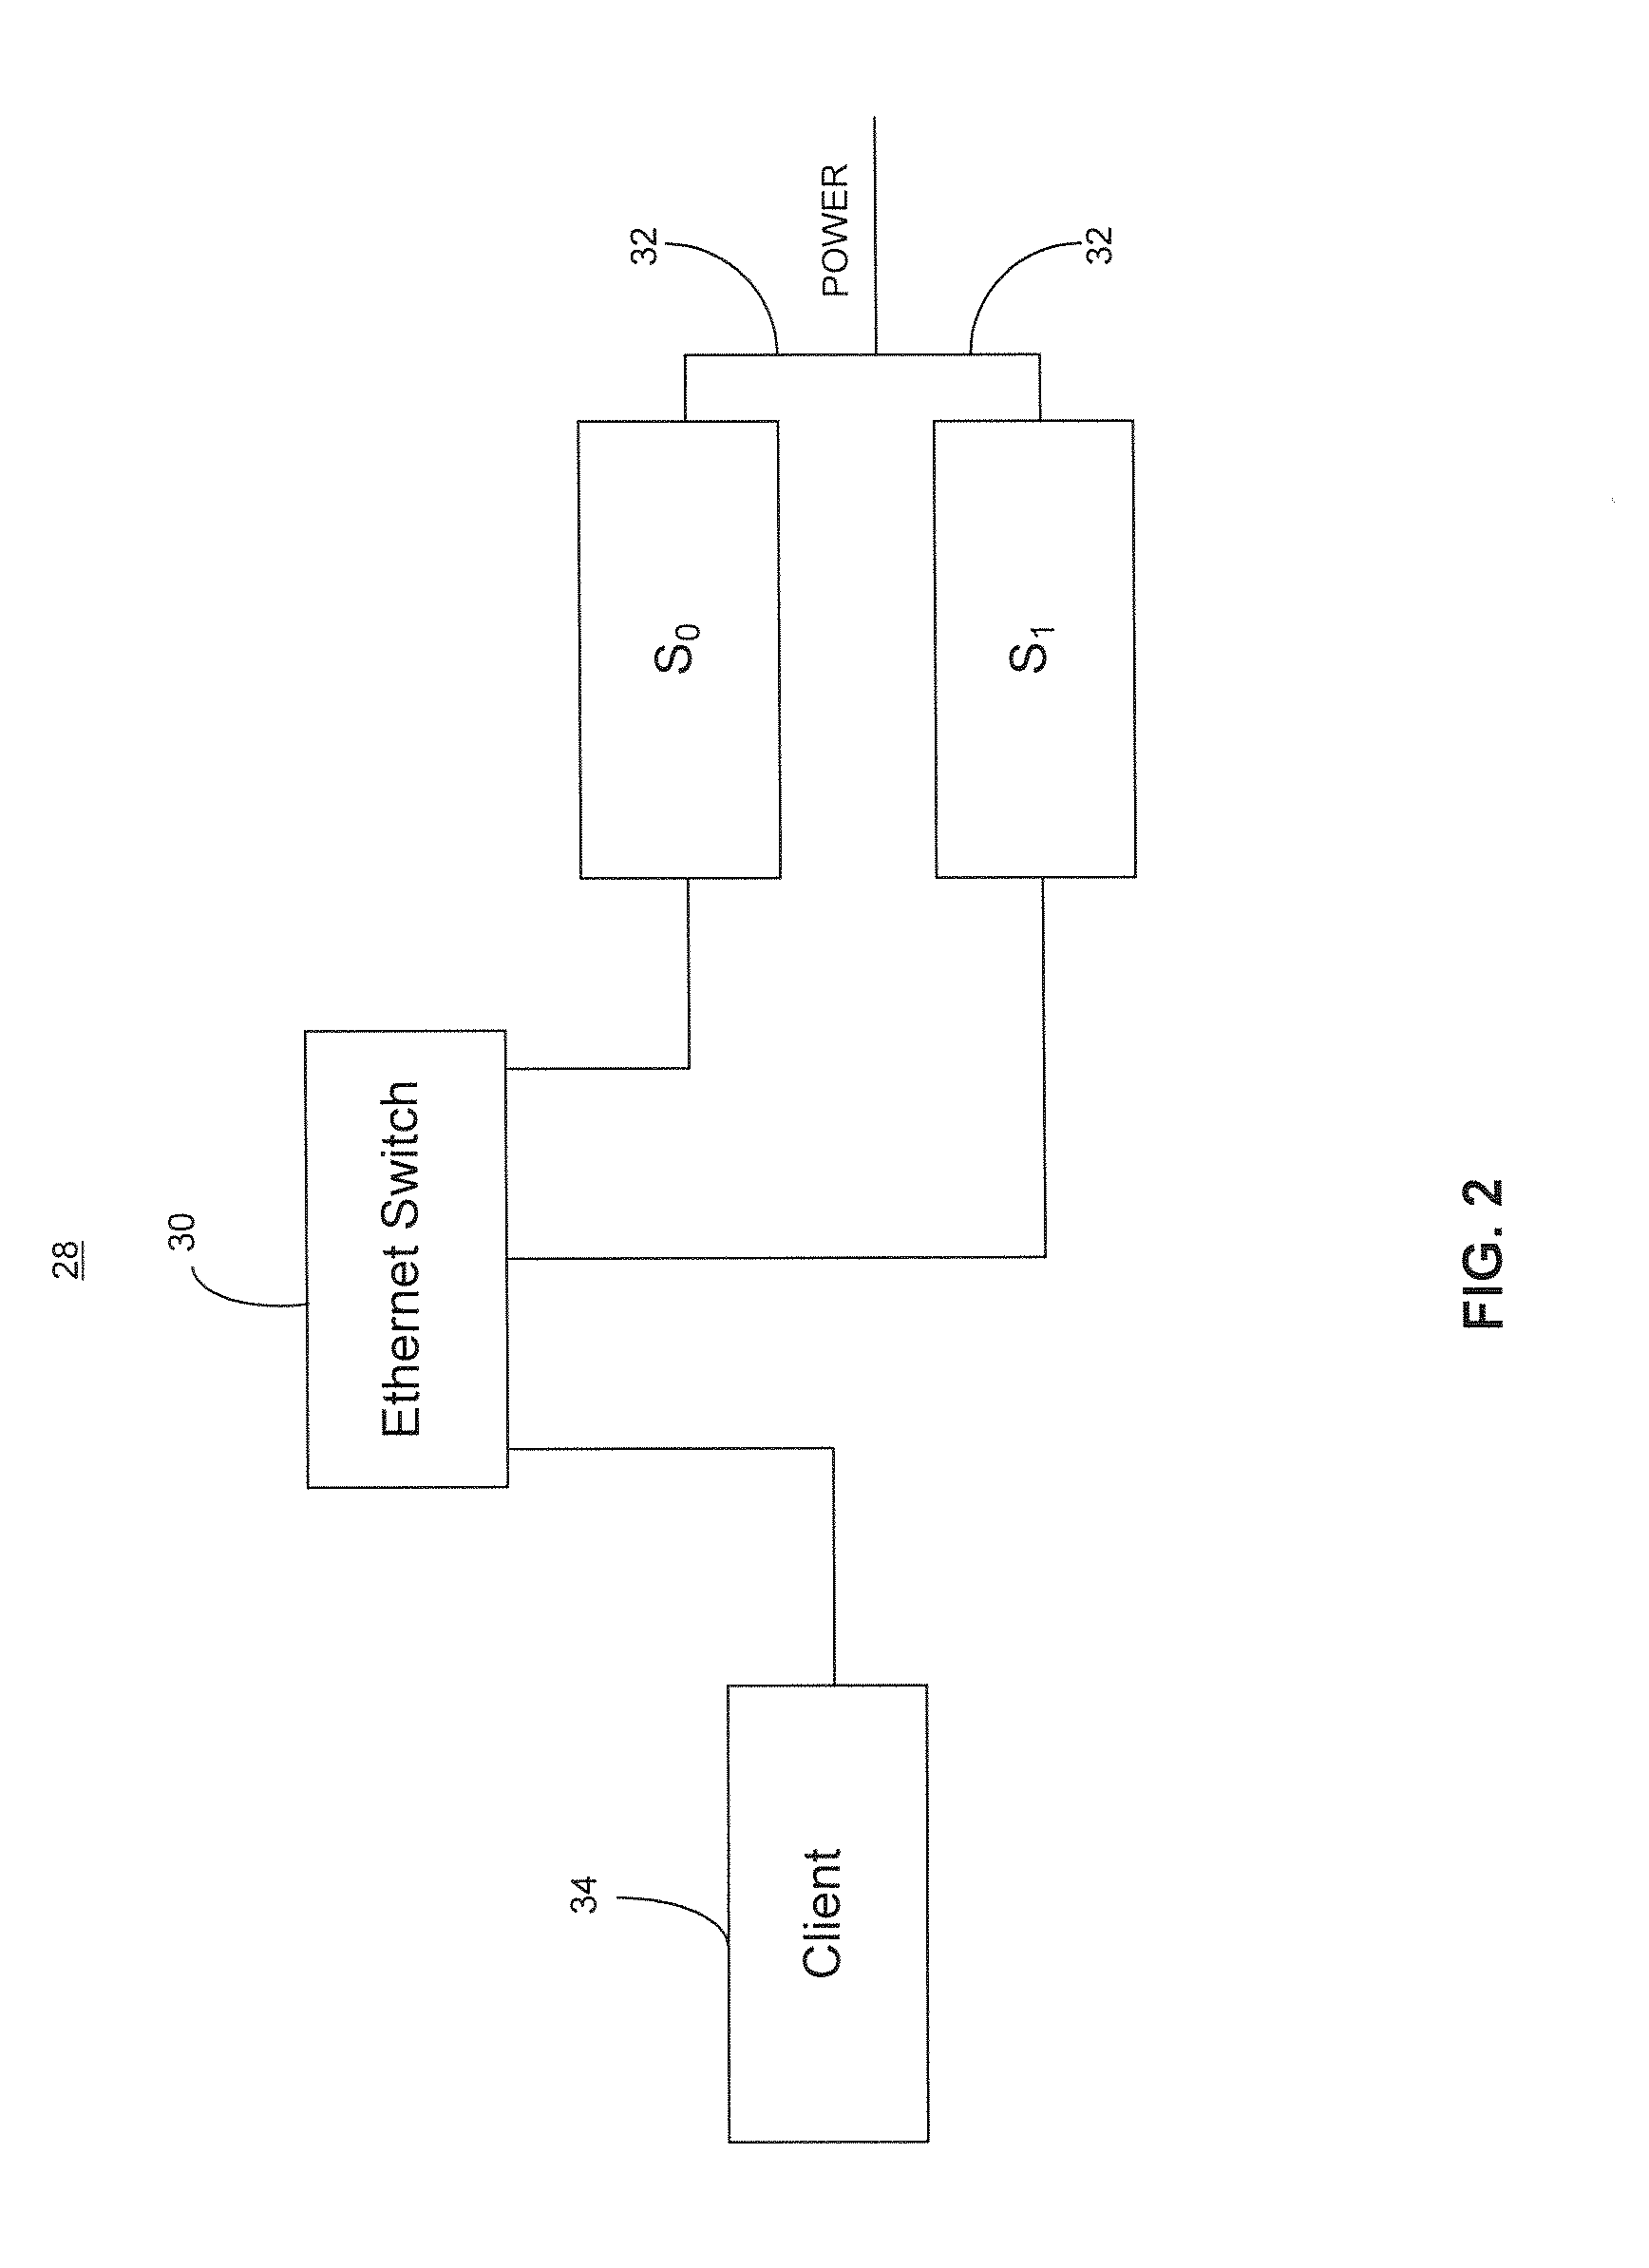
A system for imaging an area using a plurality of non-contact measurement optical sensors comprises a plurality of substantially identical sensors that detect the presence of a connected network of like sensors, accept the assignment of the role of a managing sensor or a support sensor and individually image a portion of said area. Each sensor may also individually derive image information from its image. The images or image information from each of the plurality of sensors are delivered to the managing sensor which combines them with its own image or image information and that acts as the exclusive client server for delivering the combined image or combined image information to the client.
Owner:LMI TECH
SCARA robot
PendingCN111844003AReduce weightSimple structureProgramme-controlled manipulatorPhysical medicine and rehabilitationElectric machinery
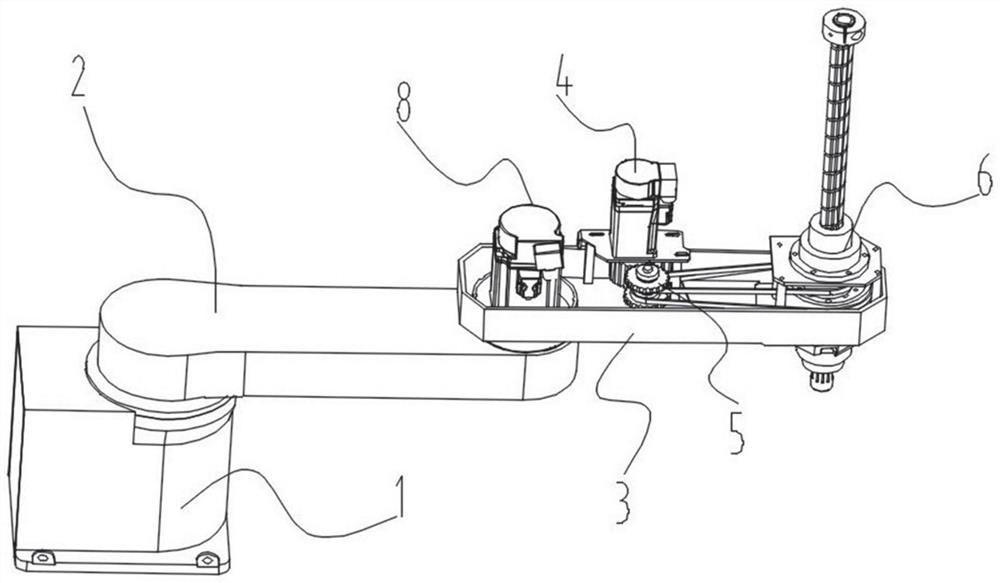
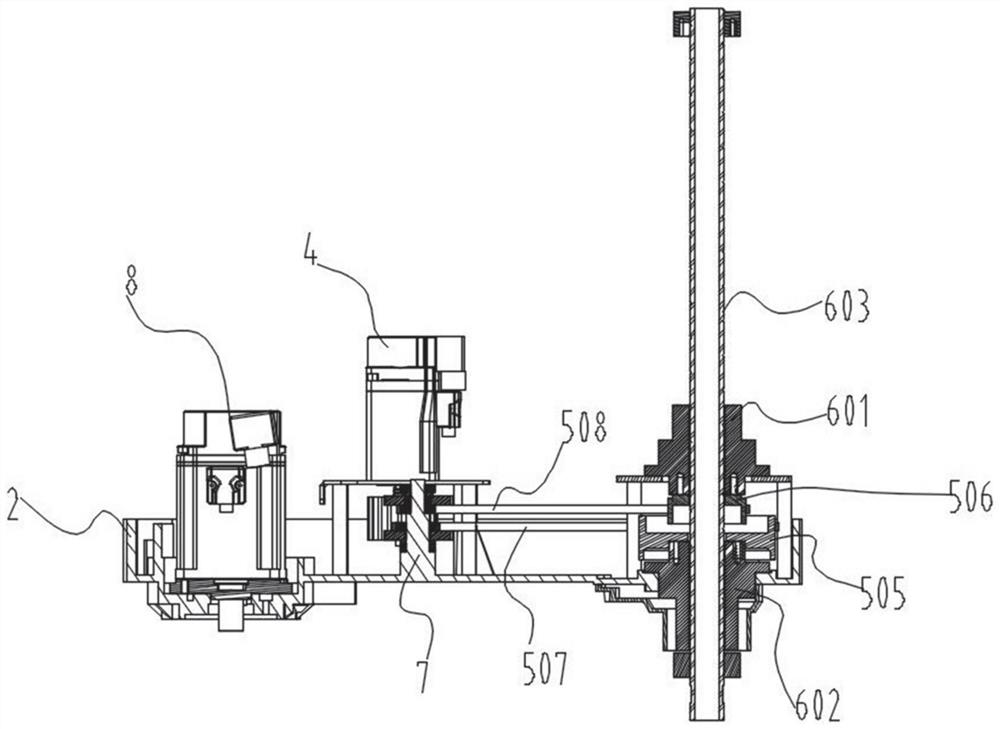
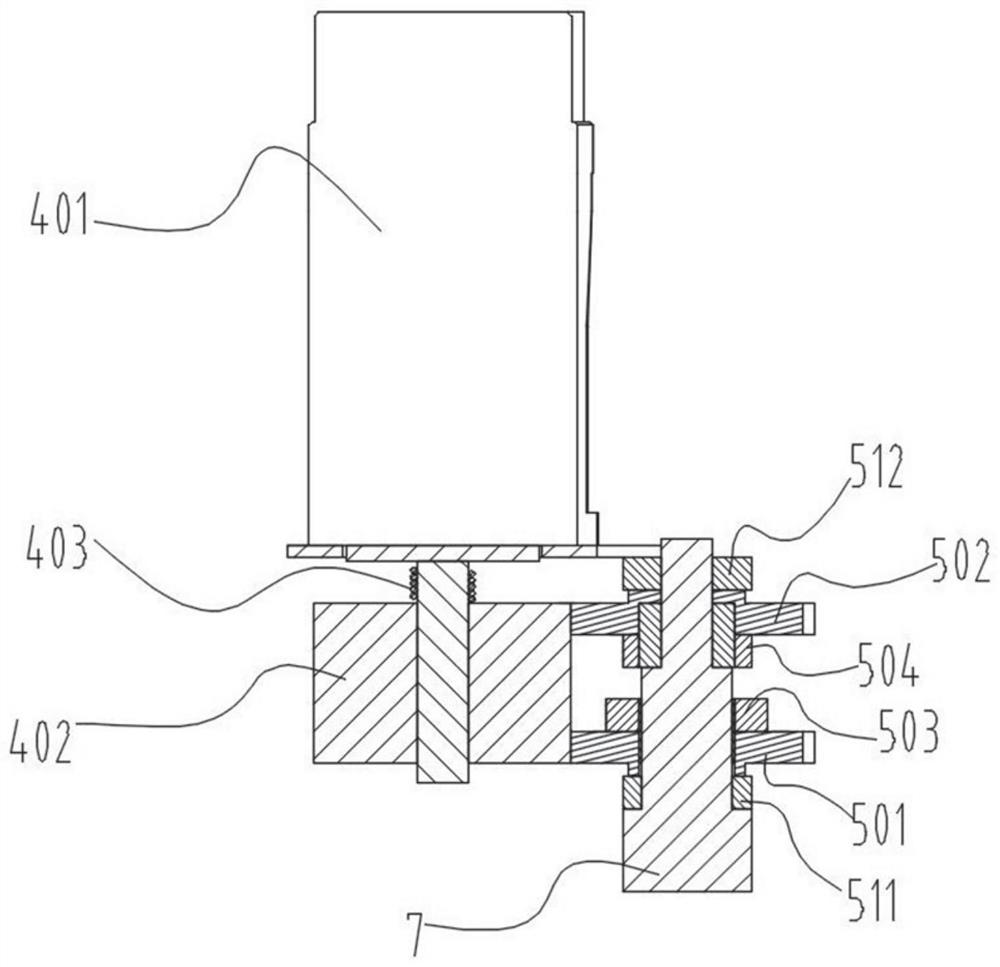
The invention relates to an SCARA robot which comprises a base, a first mechanical arm, a second mechanical arm, a transmission mechanism and an executing mechanism, wherein one end of the first mechanical arm is rotatably arranged above the base while the other end of the first mechanical arm is rotatably arranged on the second mechanical arm; a first driving mechanism, the transmission mechanismand the executing mechanism are arranged on the second mechanical arm, and the transmission mechanism is arranged at a driving tail end of the driving mechanism and is in driving connection to the first driving mechanism; the executing mechanism is arranged at the driving tail end of the transmission mechanism and achieves different working states under transmission action of the transmission mechanism, wherein the working states comprises up-down movement, rotary movement and spiral movement, so that the SCARA robot can drive the executing mechanism on the second mechanical arm to move vertically up and down, rotate and move spirally with only one motor, and therefore, the connecting cable of the robot is reduced, the bundling difficulty of the robot is reduced and the reliability of therobot is improved.
Owner:GREE ELECTRIC APPLIANCES INC
Multiple Coil Distributor and Method of Use Thereof
InactiveUS20110132339A1Easily modernize ignitionSacrificing appearanceElectric ignition installationMachines/enginesElectricityCombustion
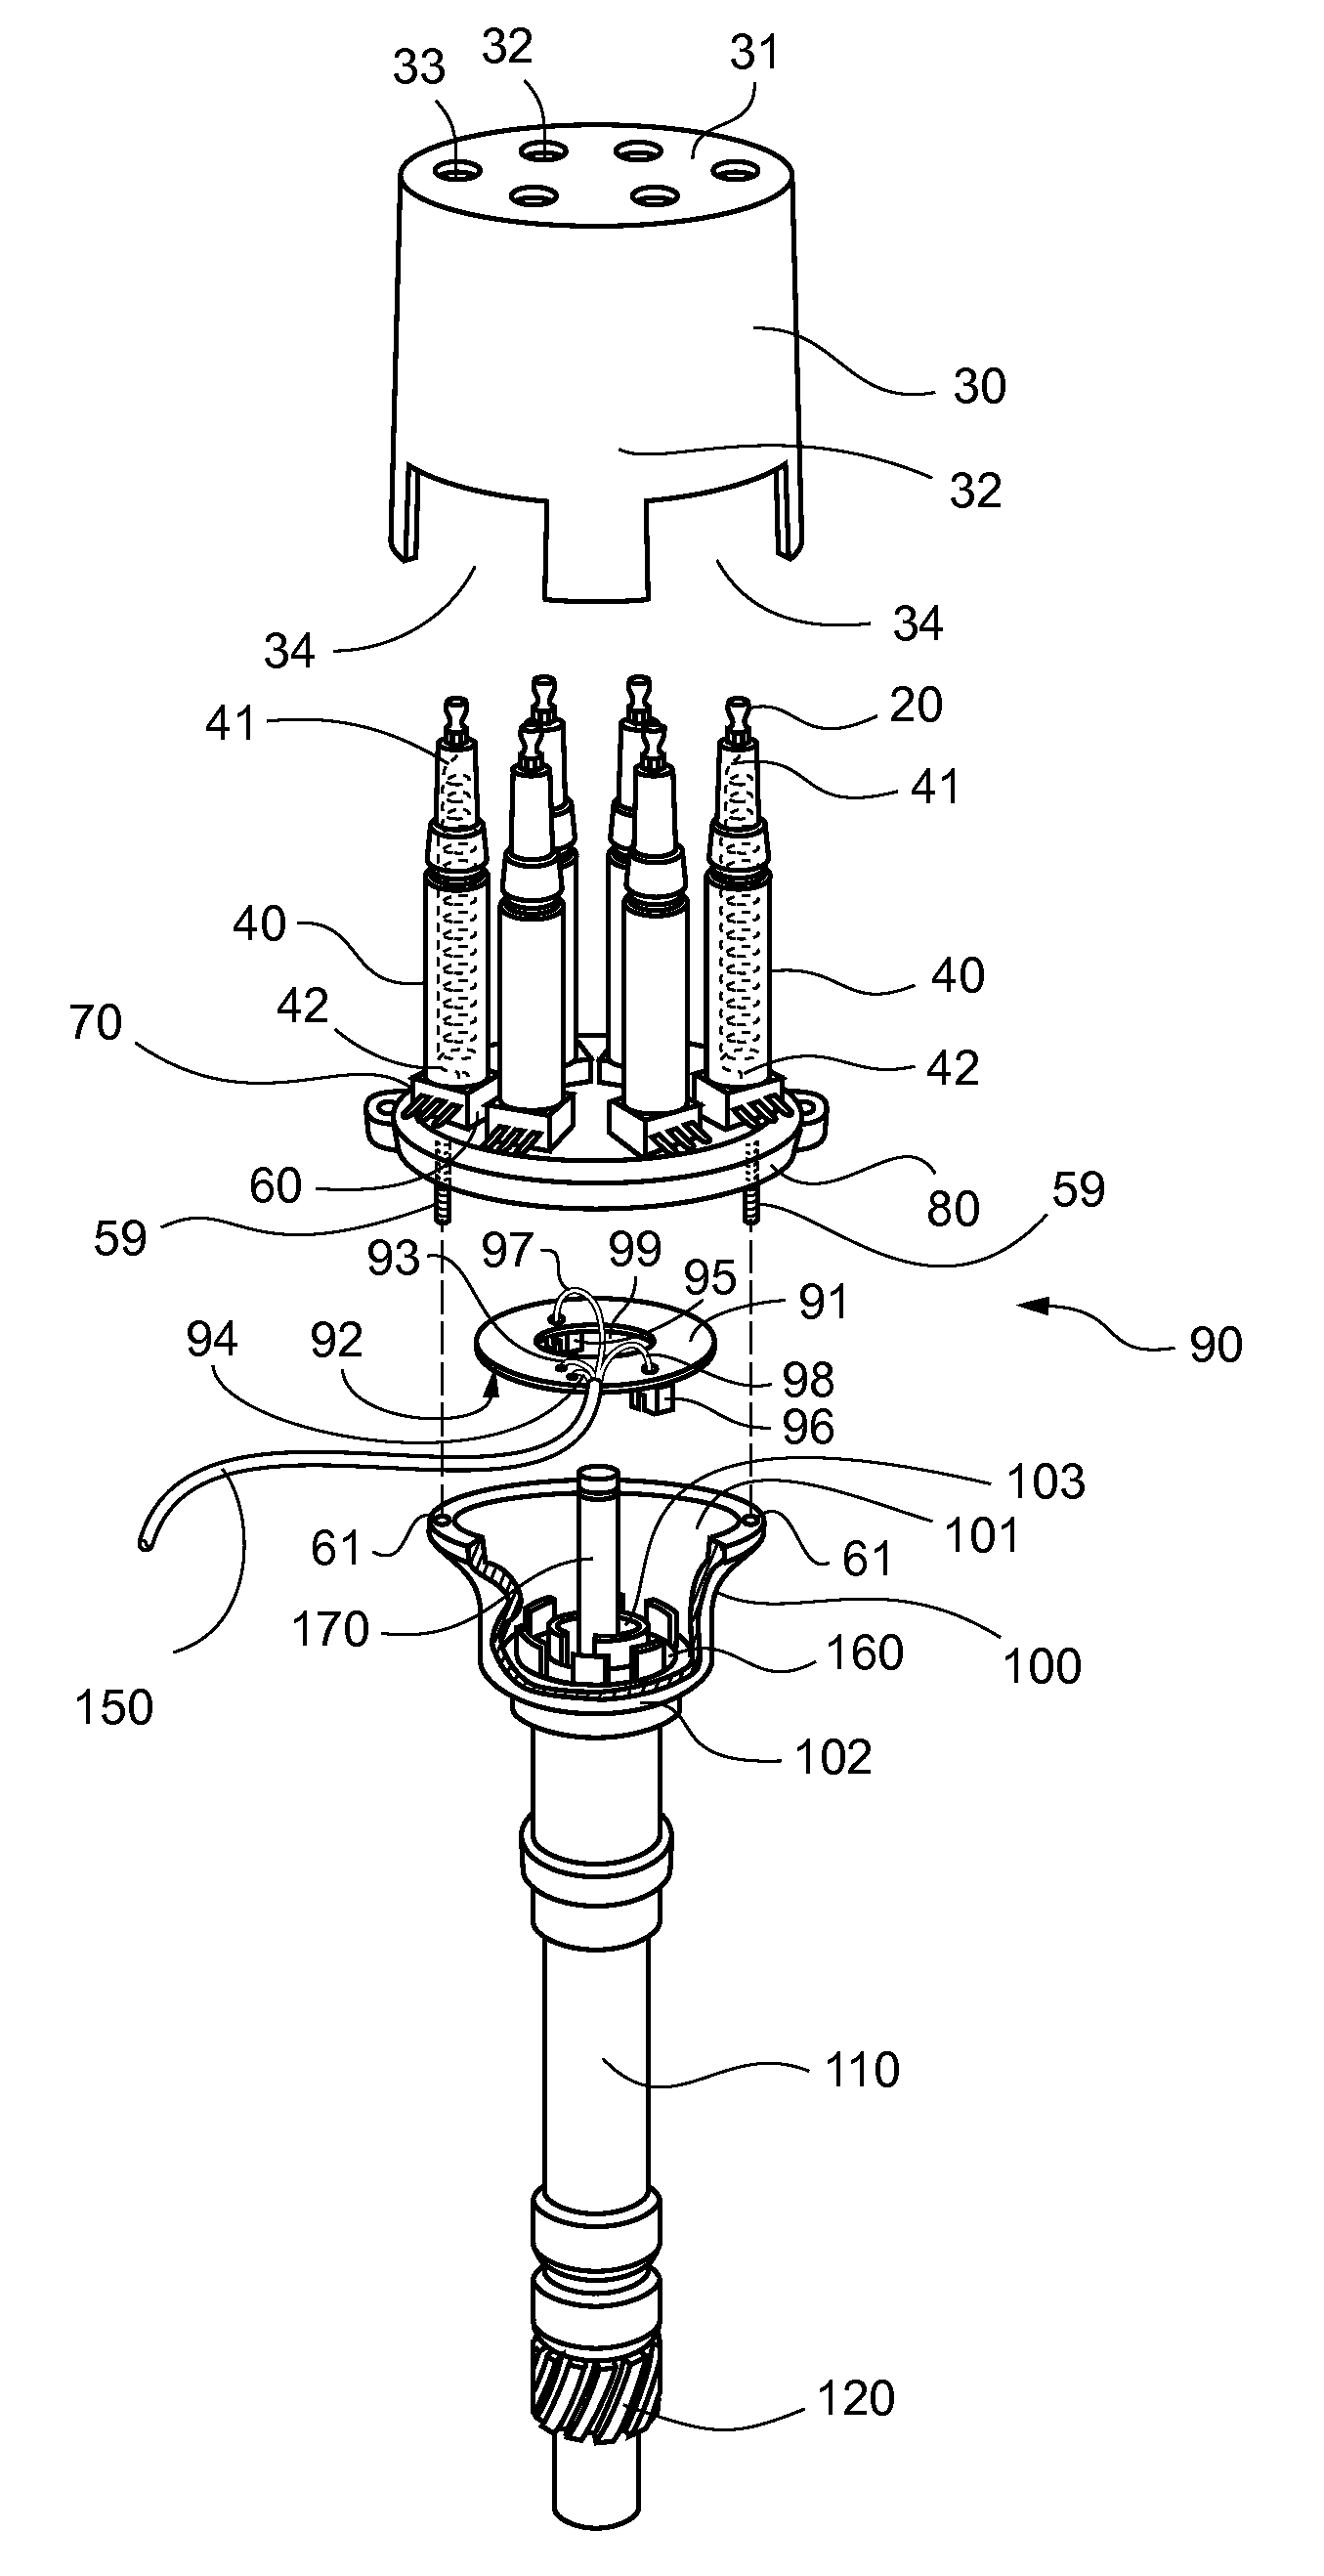
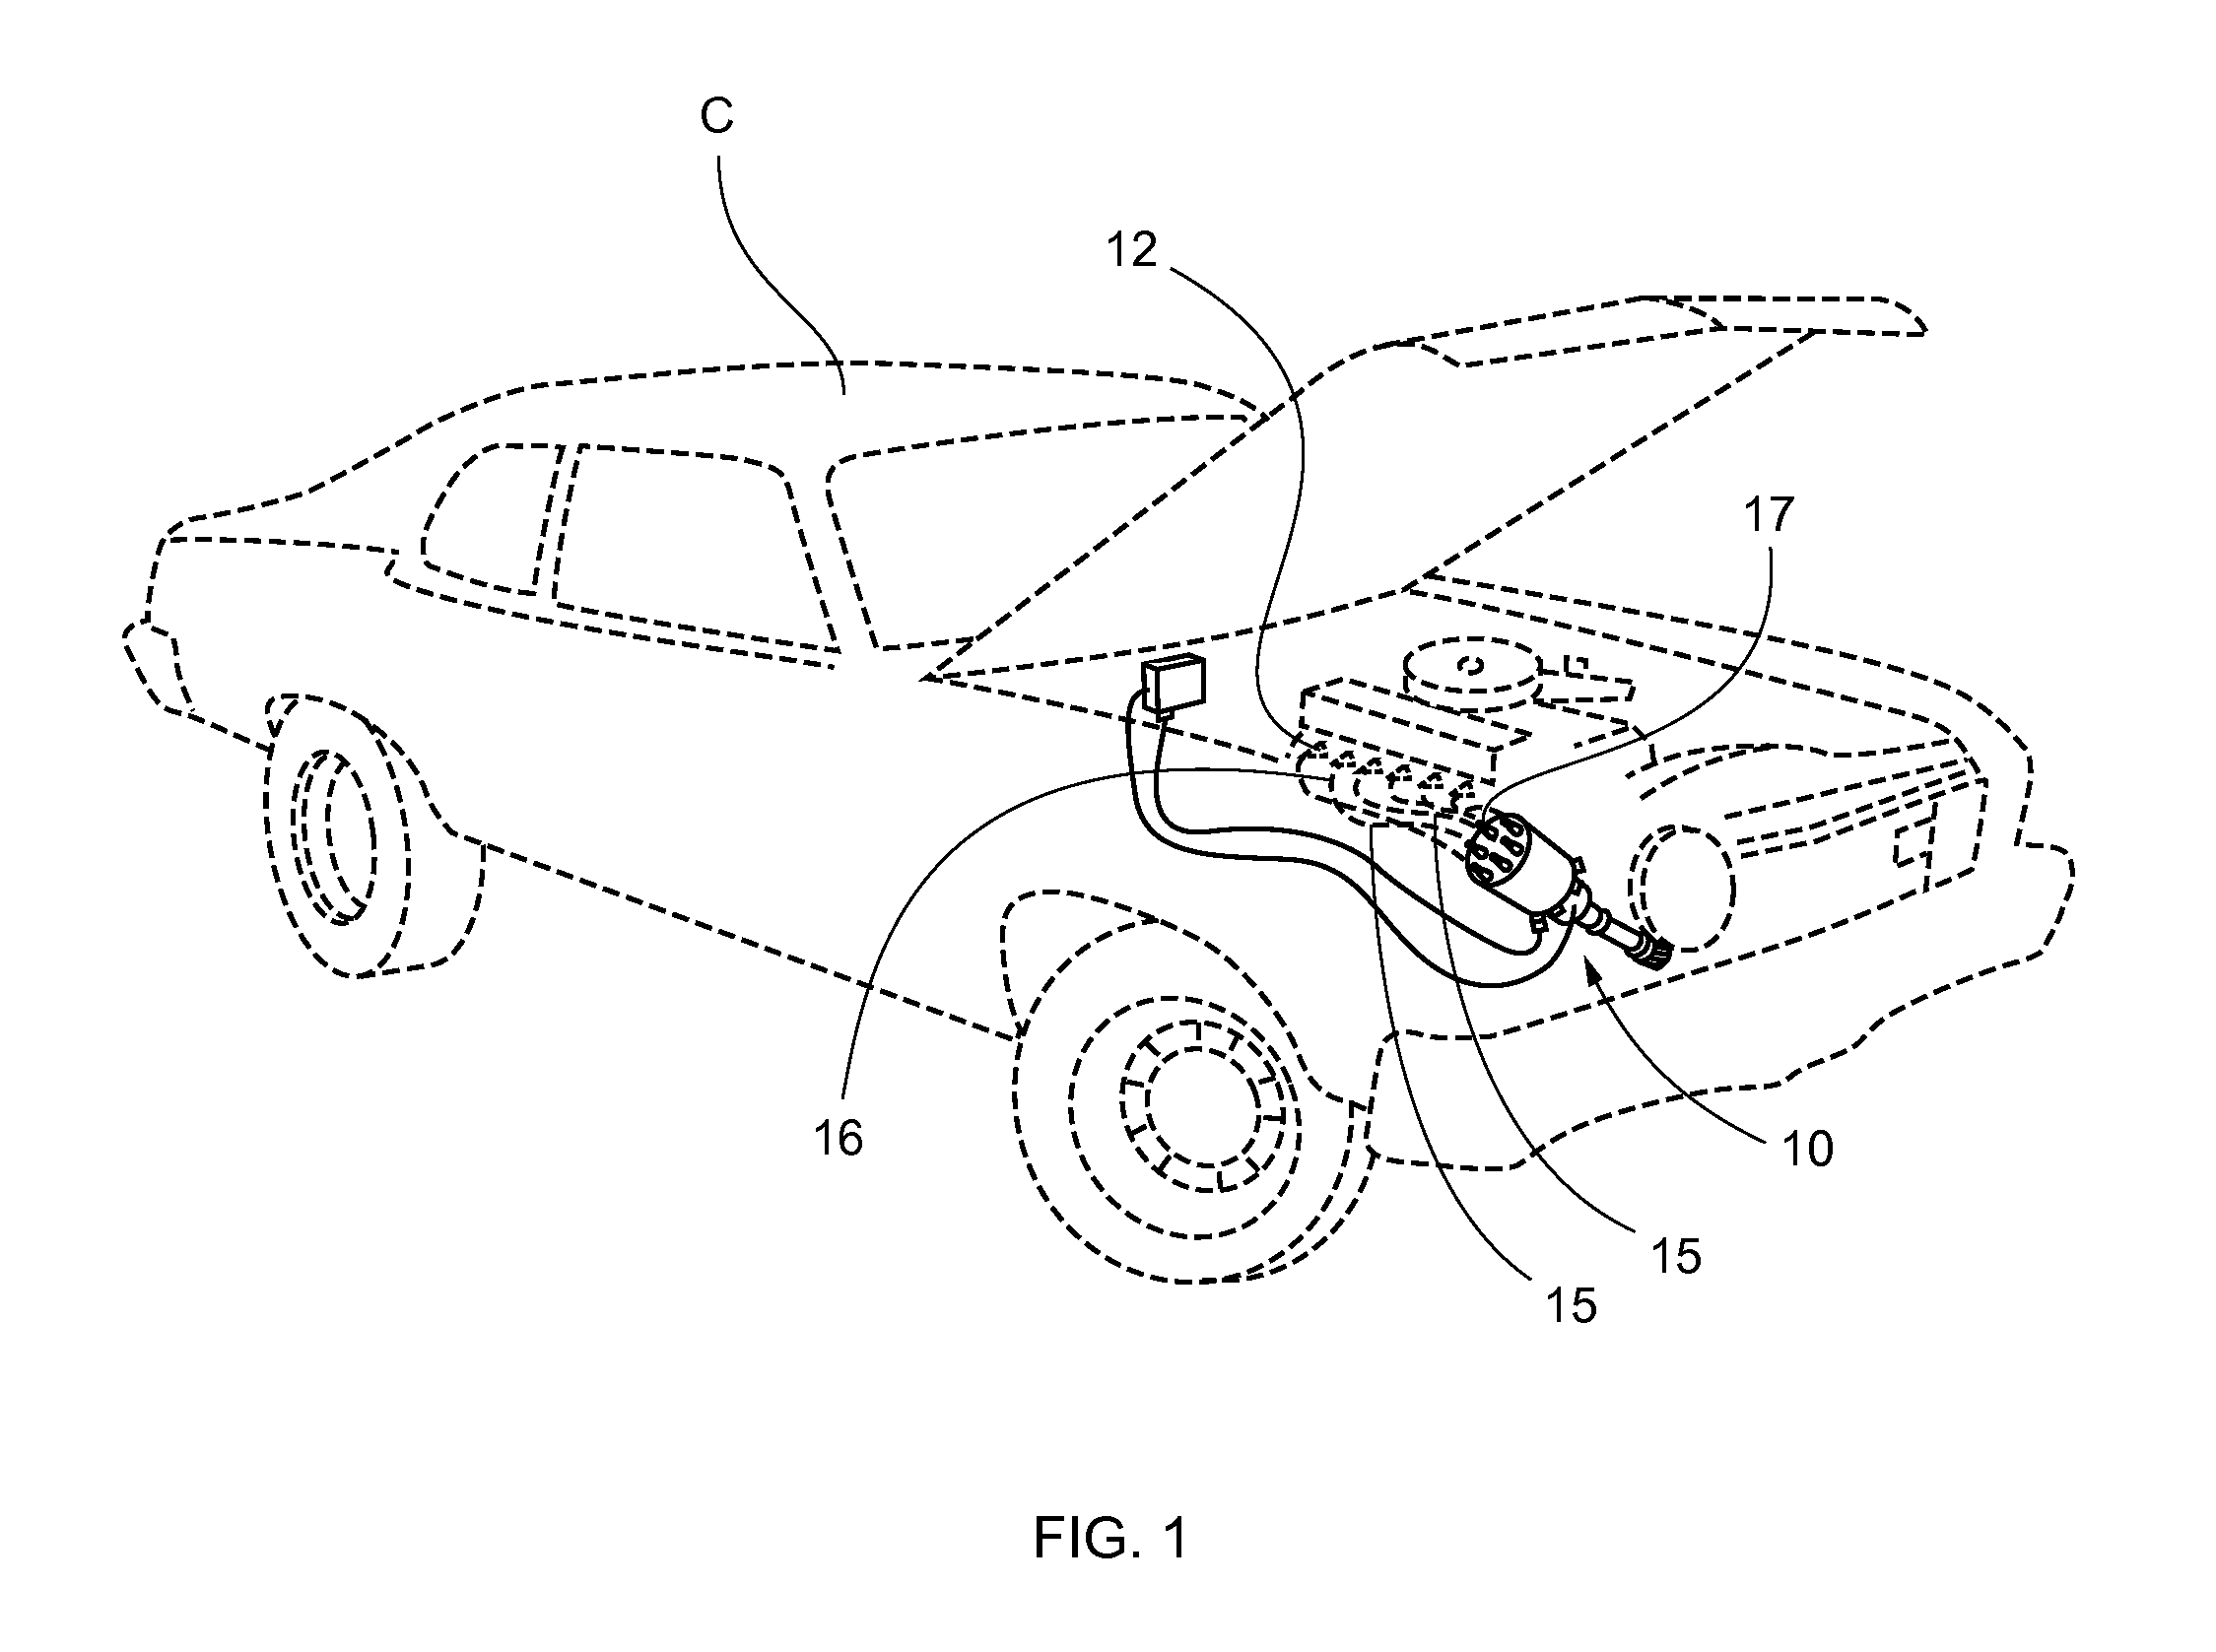
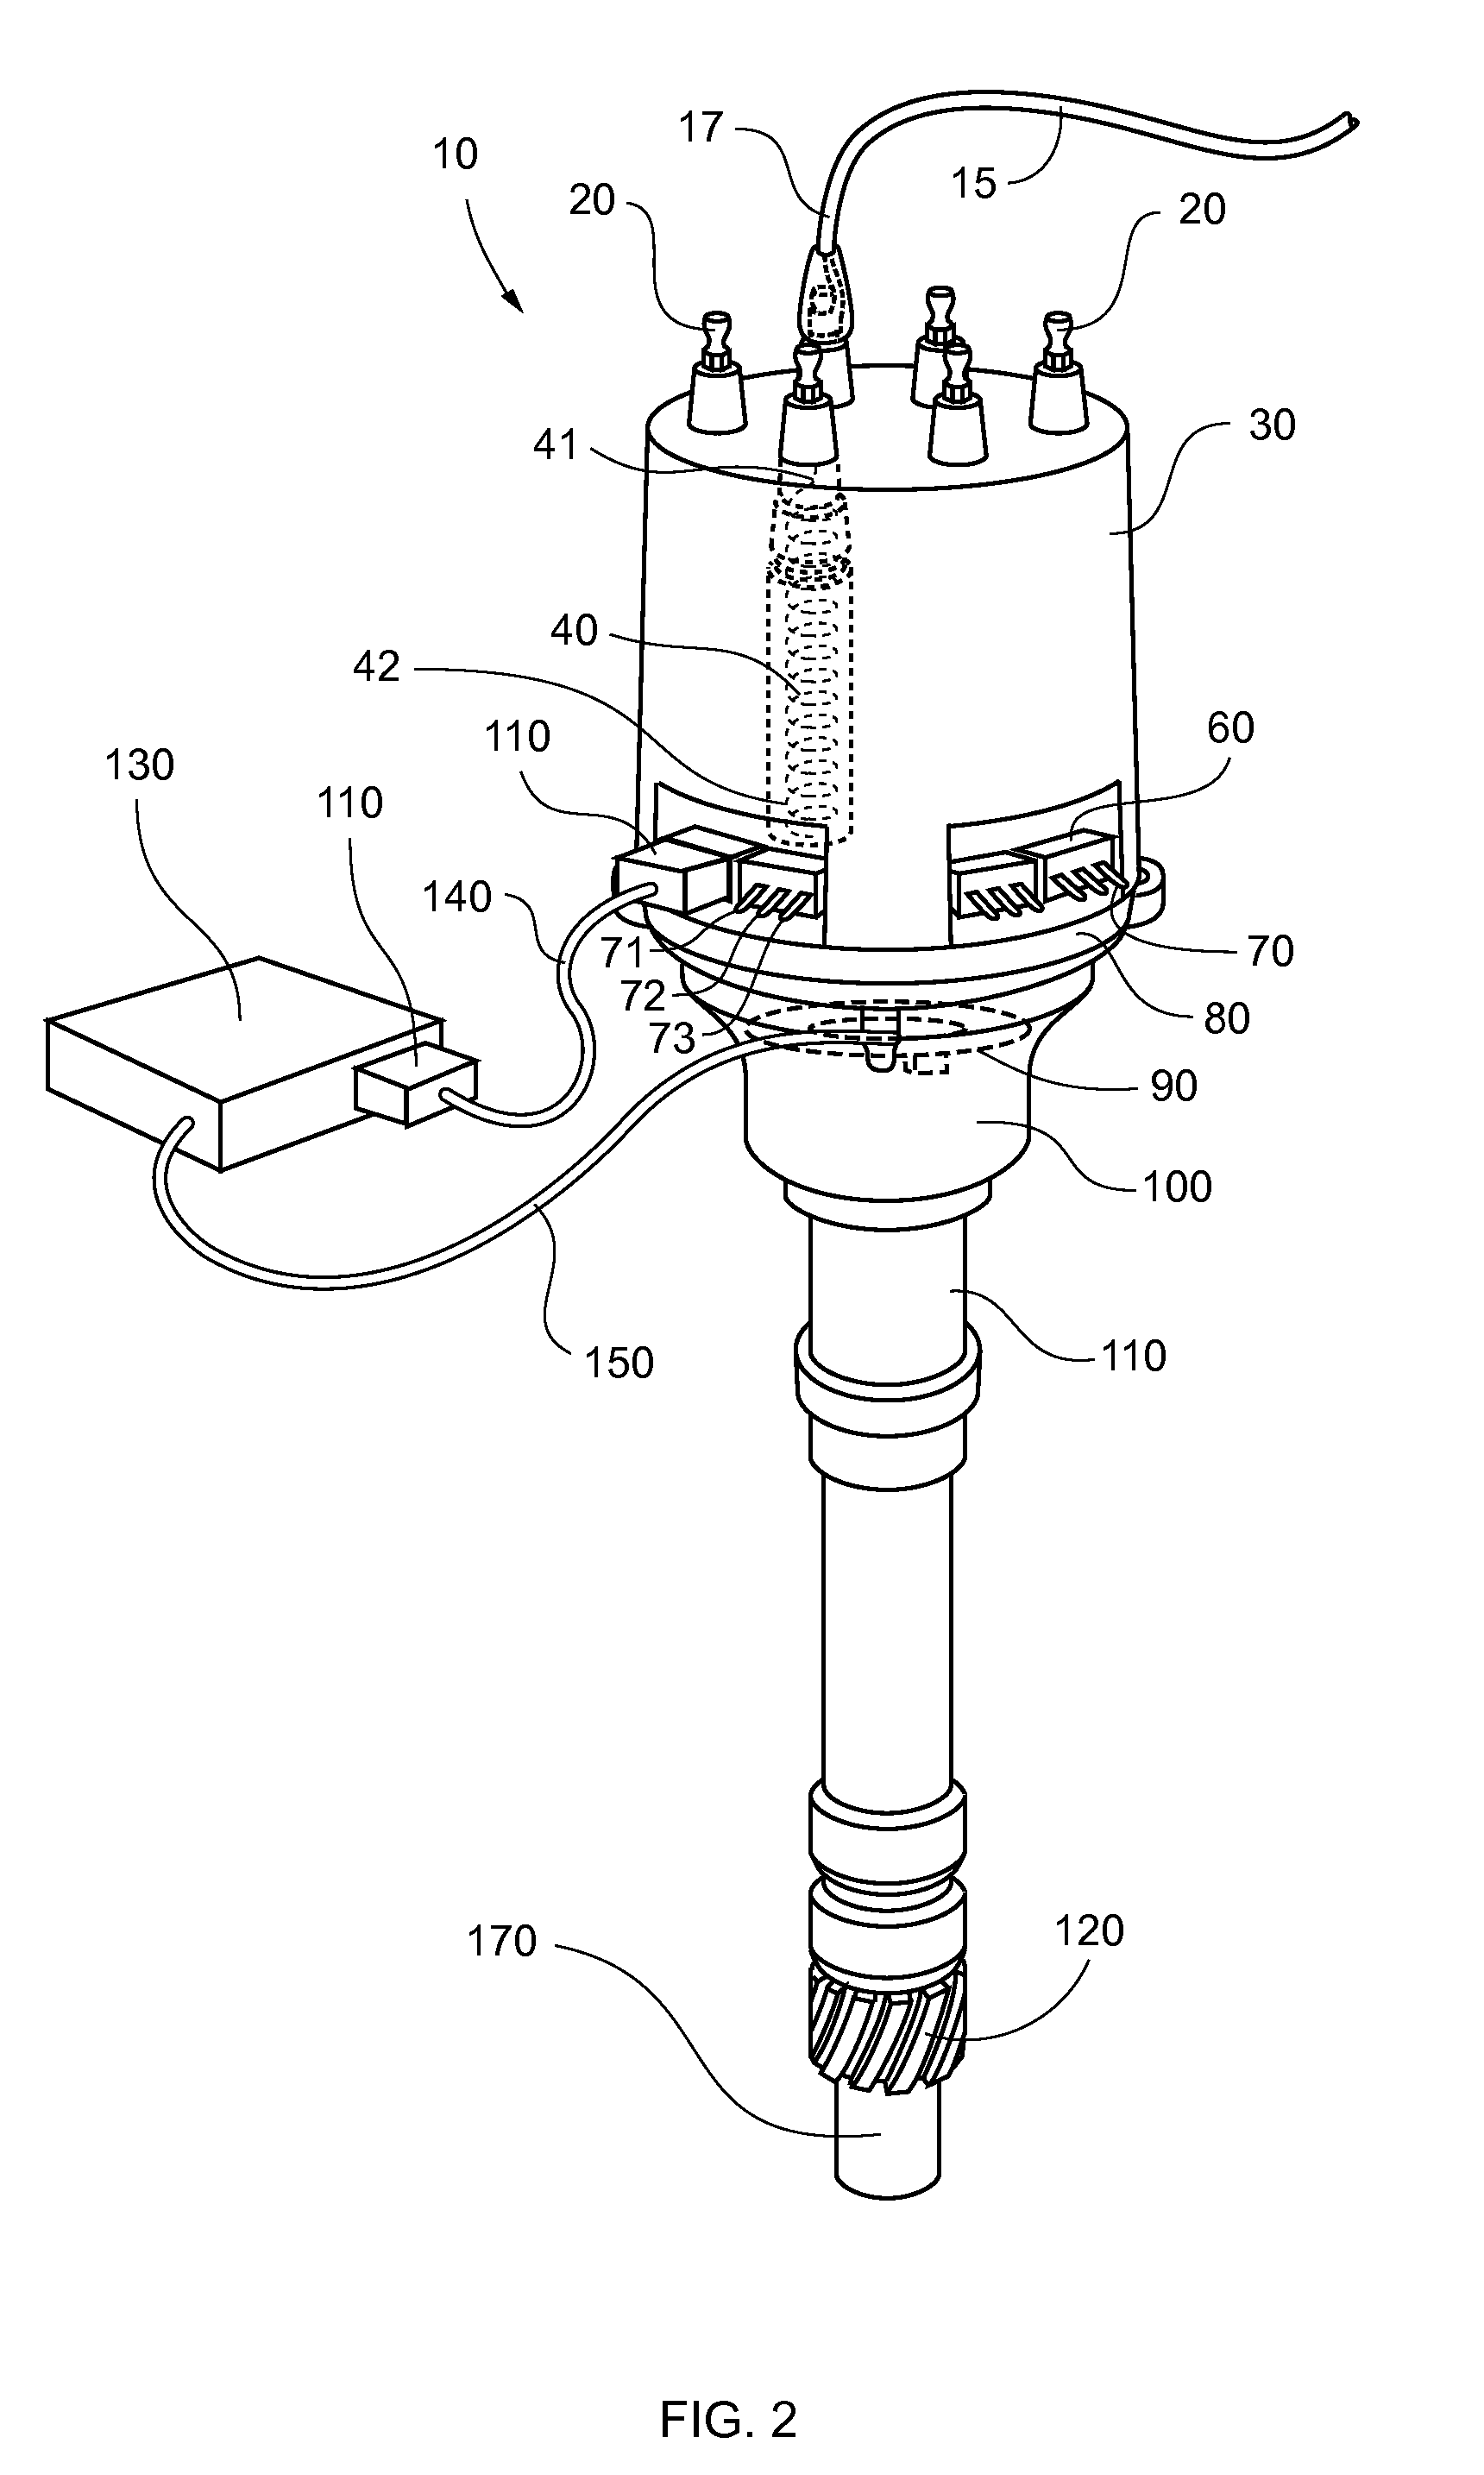
A multiple coil distributor comprising a distributor, a distributor cap and a plurality of ignition coils. The plurality of ignition coils are disposed with the distributor cap and individually connect to an associated spark plug. The multiple coil distributor further comprises an electronic control unit and a sensor mechanism. The sensor mechanism comprises a trigger wheel and is in electrical communication with the electronic control unit. Each individual ignition coil is in electrical communication with the electronic control unit. The multiple coil distributor provides a spark for an internal combustion via obtaining the multiple coil distributor, installing the multiple coil distributor within the engine compartment of a car, rotating the trigger wheel, signaling the electronic control unit via the sensor mechanism when the trigger wheel is a selected position and sparking a selected ignition coil corresponding to a selected spark plug via the electronic control unit.
Owner:HOFFMANN INNOVATIONS
Distributed-based loading control system and control method thereof
PendingCN112193181AEffective protectionReduce the risk of failureElectric/fluid circuitData controlControl system
The invention discloses a distributed loading control system, which adopts a distributed loading domain control unit, and is divided into a cab domain control unit, a tail domain control unit and an extensible domain control unit according to installation positions, and is characterized in that the loading domain control unit comprises a plastic shell, an operation button and a control panel; twoPINs are arranged on the loading domain control unit to serve as address lines; high and low levels are input for distinguishing; the cab domain control unit collects opening and closing signals, cabcontrol buttons, interface addresses and loading system model selection information, and a driver is informed of the working state of a loading system through sound and an indicator lamp. The tail domain control unit collects opening and closing signals, a vehicle tail control button, an interface address and state data of a loading executing mechanism and controls the loading executing mechanismto act. According to the invention, the loading function can be flexibly selected through the electrical function interface of the loading domain control unit, and the system can be suitable for various pure electric special vehicles without changing the loading control system, and is convenient and reliable.


Owner:NANJING GOLDEN DRAGON BUS
Information Handling System Radio Antenna Selection and Control
ActiveUS20170310002A1Improve wireless performanceImprove robustnessCriteria allocationTelephone set constructionsRadio equipmentEngineering
A portable information handling system rotationally couples main and lid housing portions to each other with a hinge having opposing faces. One of a first or second antenna set disposed on the opposing faces is selected to support wireless communication by a radio disposed in the housing based upon the rotational orientation of the hinge. Optimal antenna selection is confirmed by comparing return signal strength indicator or bit rate error of the first and second antenna sets.


Owner:DELL PROD LP
Gantry type hyperspectral image collecting system for gardening plantlet crops
PendingCN107091813AReduce cablesOr shorten the cableColor/spectral properties measurementsMicro computerAgricultural science
The invention belongs to the technical field of modern agriculture and discloses a gantry type hyperspectral image collecting system for gardening plantlet crops. A servo motor is fixed to the upper portion of a support through bolts, the servo motor is connected with a movable platform through a synchronous belt, two ends of the movable platform are in slide connection with slide rails, and the slide rails are arranged on two sides of the upper portion of the support; a hyperspectral camera, a micro computer, a battery and an initiative light source lamp are fixed to the movable platform through bolts; the hyperspectral camera is connected with the micro computer through an optical fiber, the micro computer is connected with a notebook computer and the like through WiFi (Wireless Fidelity), and the notebook computer can control the hyperspectral camera to collect images and the servo motor to drive the movable platform to move. The gantry type hyperspectral image collecting system disclosed by the invention can collect hyperspectral images of varieties of gardening plantlet crops and is simple in structure and convenient to operate.

Owner:EAST CHINA JIAOTONG UNIVERSITY +1
Cleaning and charging station
ActiveUS11148308B2Minimizing risk of malfunctionRisk minimizationCircuit monitoring/indicationDifferent batteries chargingGallowsElectrical drive
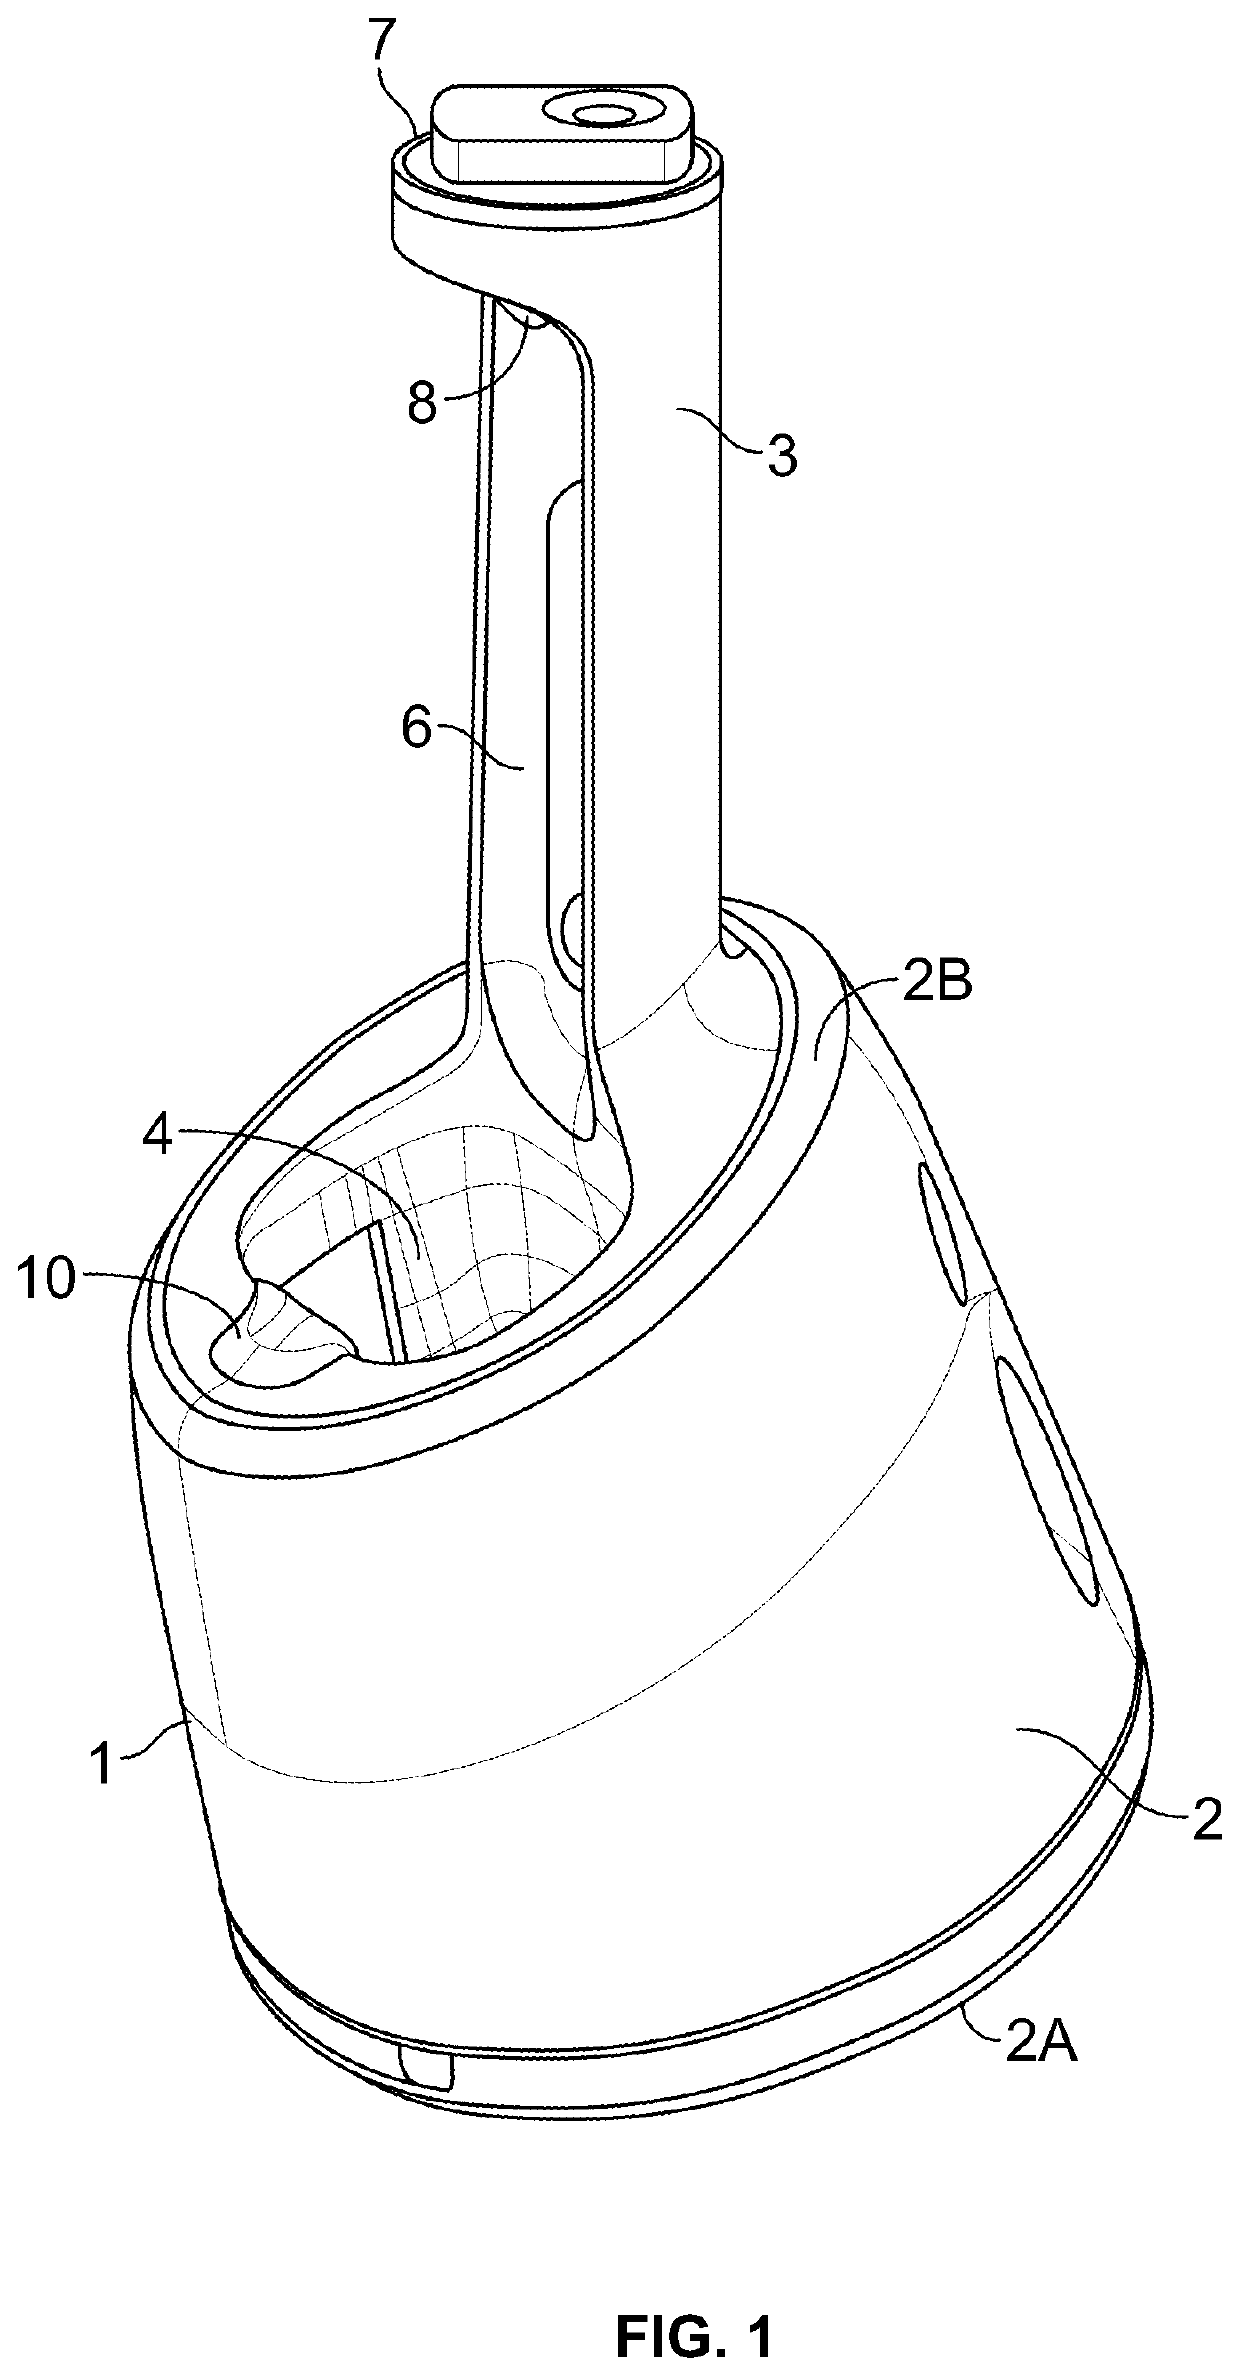
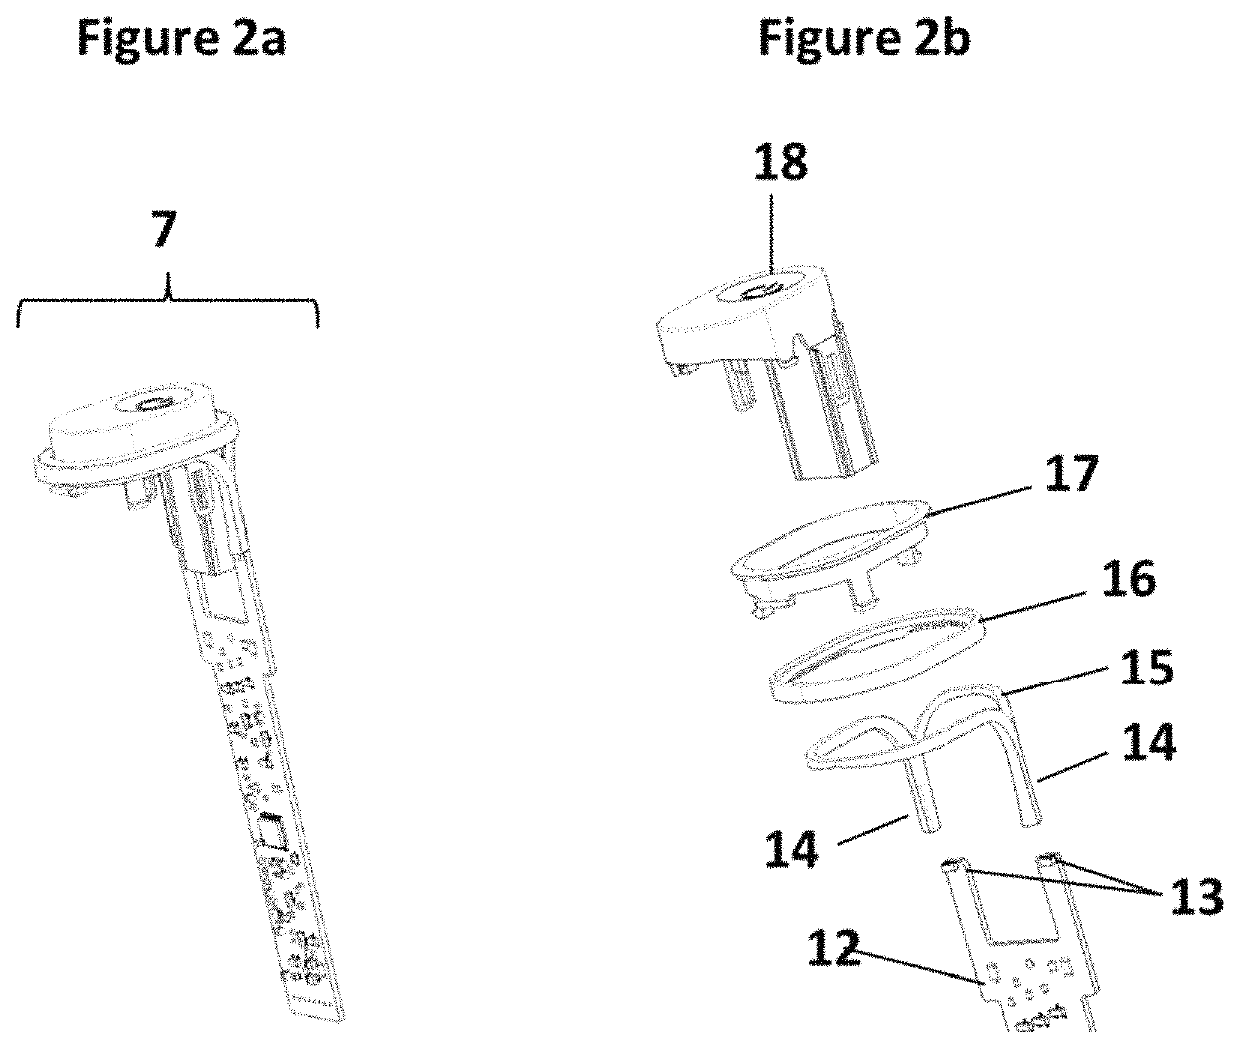
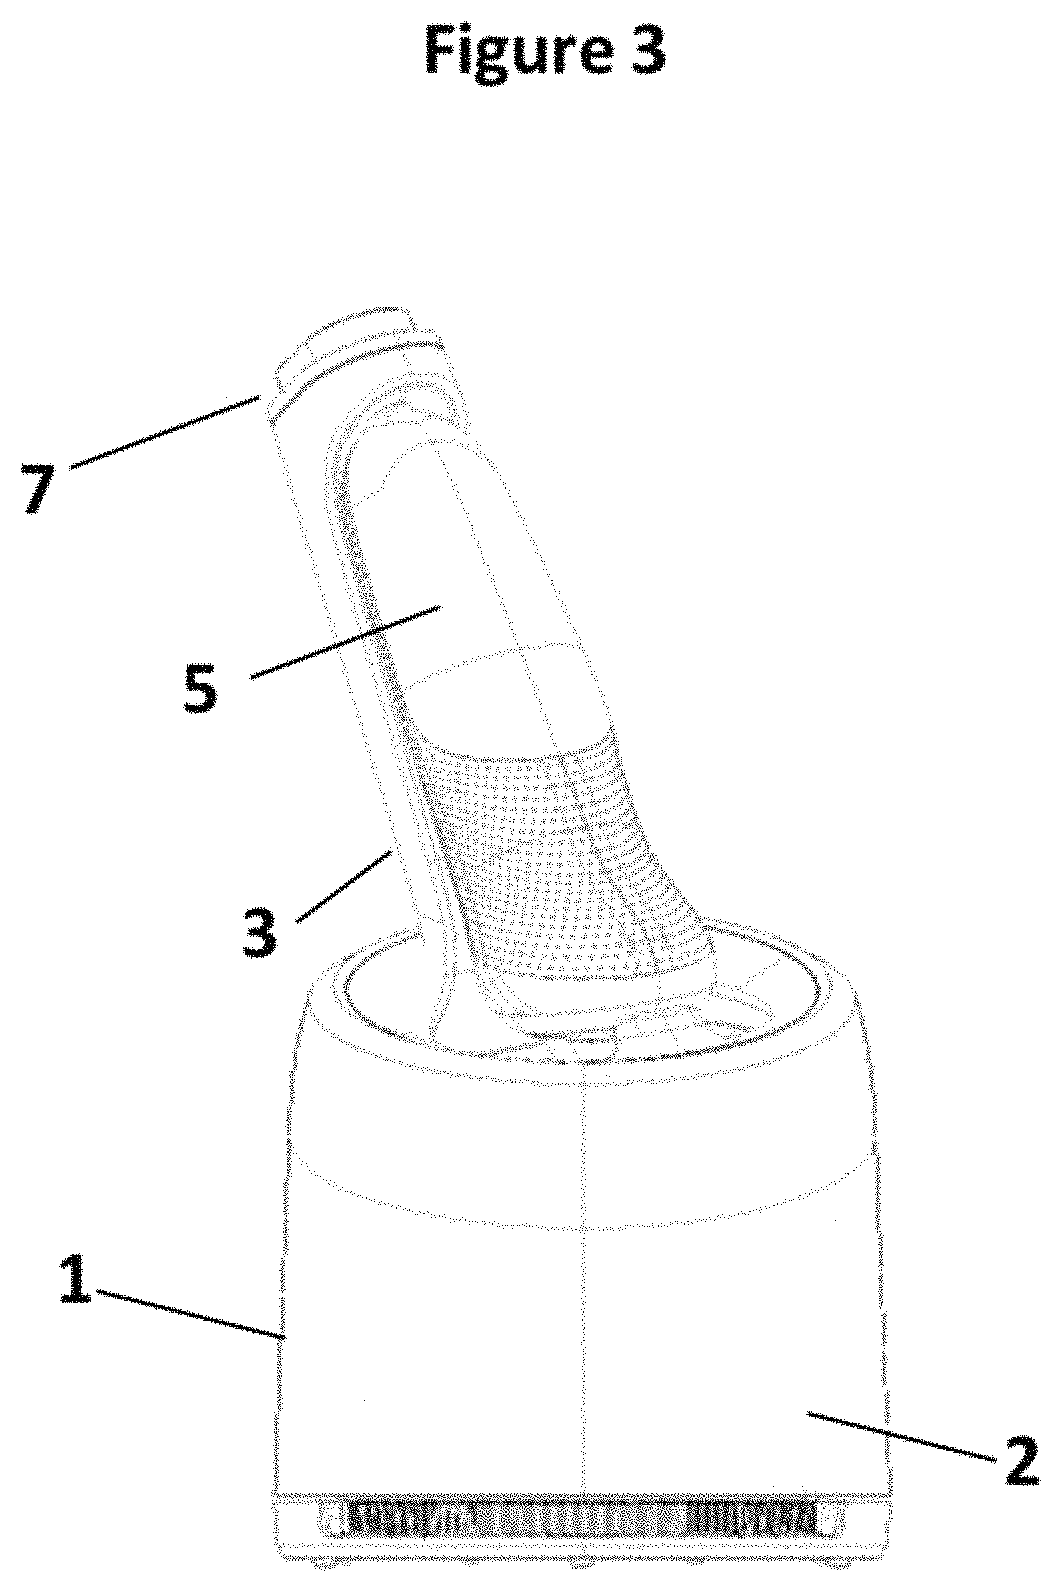
Owner:BRAUN GMBH
Driver for radar servo system
InactiveCN104158470AReduce application equipment and cablesReduce equipment costsElectric motor controlHuman–machine interfaceInput/output
The invention discloses a driver for a radar servo system. The driver is used for driving a direct current motor or an alternating current motor. The driver comprises a control module, a drive module, a communication module, an analog input / output module, a digital quantity input / output module, a position / speed detection module, a human-machine interface module, a power module, a current detection module and a detection and protection module. The control module is connected with the parts of the driver and used for conducting coordination control over the parts of the driver so as to drive the motor. The drive module is used for driving and controlling the motor. The communication module is used for controlling communication between the driver and the motor. The position / speed detection module is used for detecting the position and the speed of the motor. The current detection module is used for detecting the magnitude of two-phase currents output by the drive module, converting the two-phase currents into voltage signals and then transmitting the voltage signals to the control module for current loop closed-loop control. The detection and protection module is used for monitoring currents and voltages of the driver.


Owner:CHINA ELECTRONIC TECH GRP CORP NO 38 RES INST
Method for realizing optional upgrade of wireless access box by network port
InactiveCN101610292AReduce work stations and cablesImprove download speedData switching detailsUpgradeHandshake
The invention relates to a method for realizing optional upgrade of a wireless access box by a network port. The method comprises the following steps: detecting whether the wireless access box needs to be upgraded by a PC, if so, sending a communication link handshake instruction, then analyzing a data packet after receiving a handshake success data packet, extracting a characteristic message of the wireless access box and prompting a user to select the option to be operated by the PC; then forming a data packet by the user option and parameters needed by completing the user option, and sending the data packet to the wireless access box; and analyzing the data packet, then executing corresponding operation, and returning an execution result by the wireless access box. The method reduces stations and cables, and improves downloading speed and production efficiency in production on one hand, and reduces external interfaces of the wireless access box when the user uses the wireless access box on the other hand. A single data cable does not need to be provided for a client so as to simplify the user operation, which can effectively improve satisfaction degree of the user.


Owner:ZTE CORP
Rear brake device of vehicle
InactiveCN107878658ARealization of small size and light weightReduce pipingAxially engaging brakesMotorised scootersCalipersParking brake
A rear brake device of a vehicle is provided. A service brake caliper (50) and the parking brake caliper (hereinafter called P caliper) (90) are supported by a swing arm (20) rotatably supporting therear wheel (WR). The service brake caliper (50) and the P caliper (90) are configured to brake the brake disc (36). In the rear brake device of the vehicle, the service brake caliper (50) and the P caliper (90) are fixed to a stay member (40), the stay member (40) being supported by the swing arm (20). At least some of the service brake caliper (50) and the P caliper (90) are arranged in positionsforward of a vehicle body and upward of the vehicle body from an axle (37) of the rear wheel (WR). A first boss (54) and a third boss (93) are arranged on a straight line (L) passing through a centerpoint (O) of the axle (37).
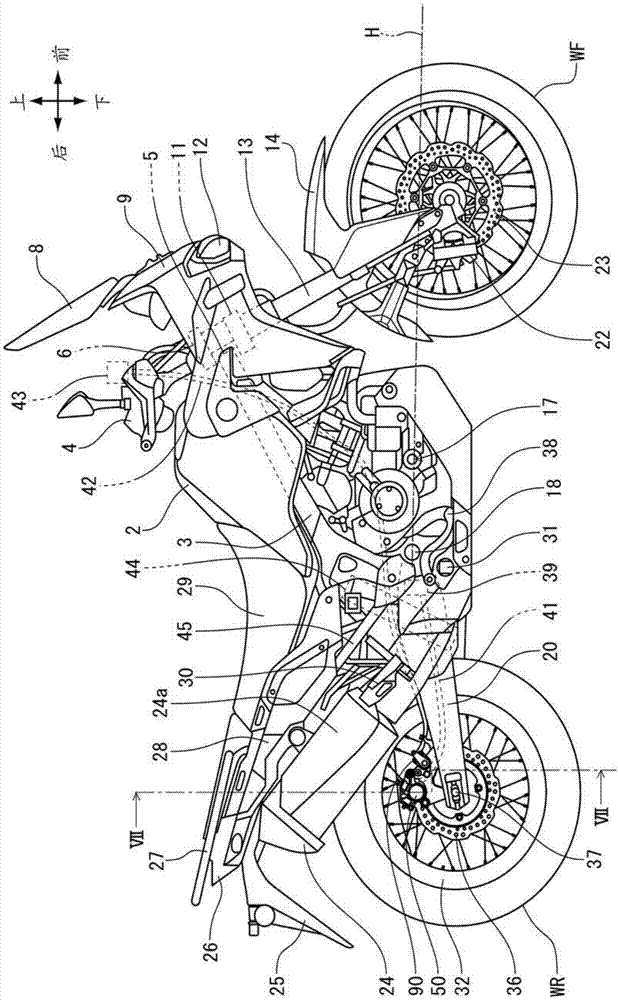
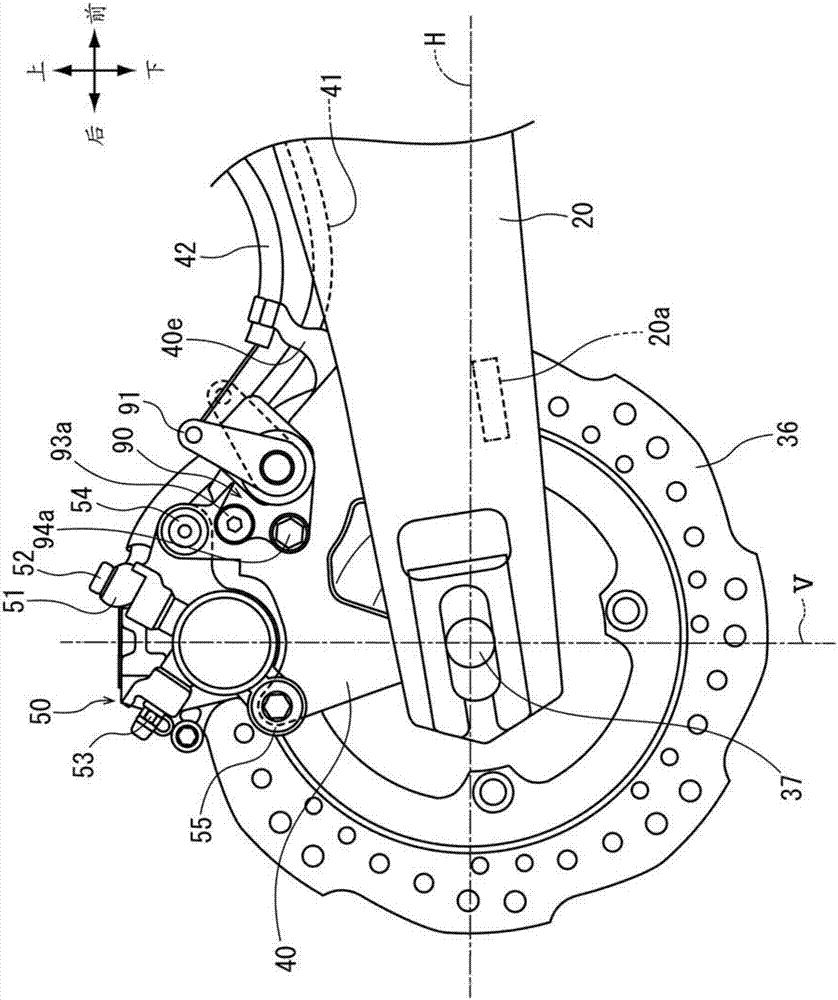
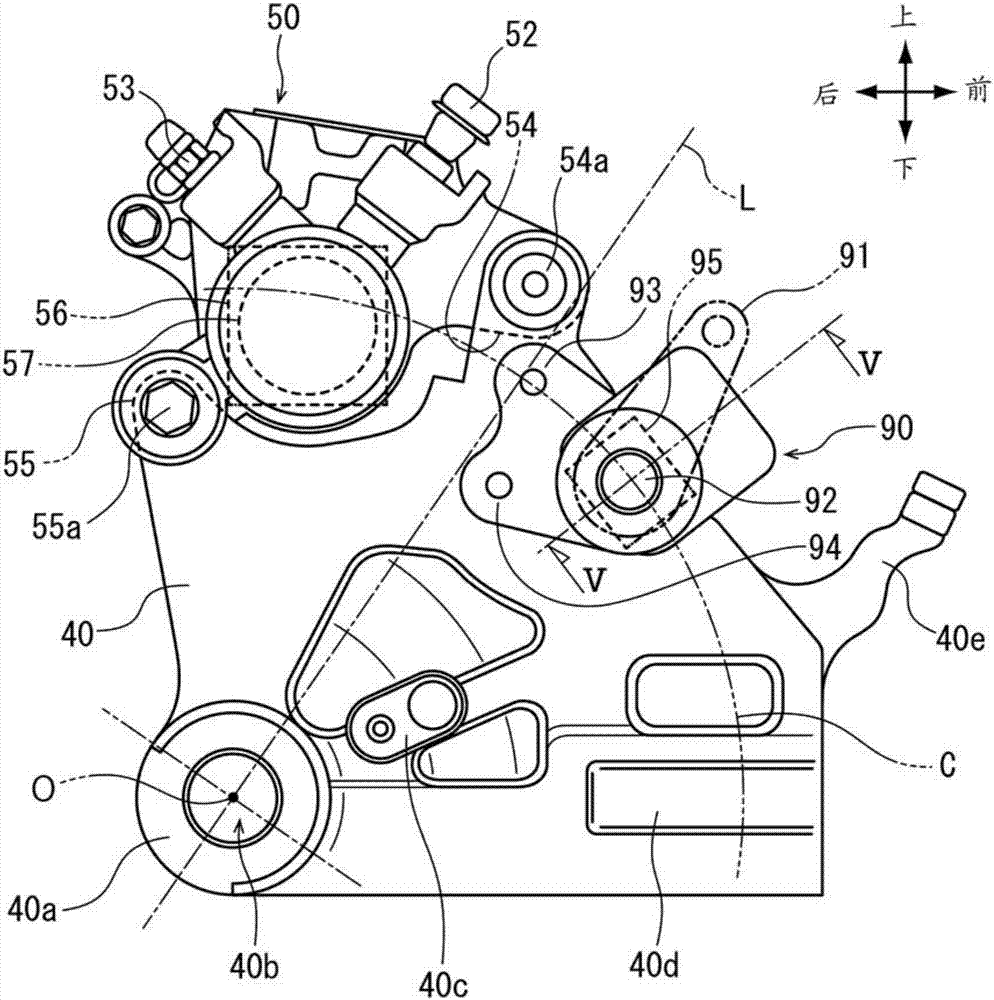
Owner:HONDA MOTOR CO LTD
Floating roof monitoring with laser distance measurement
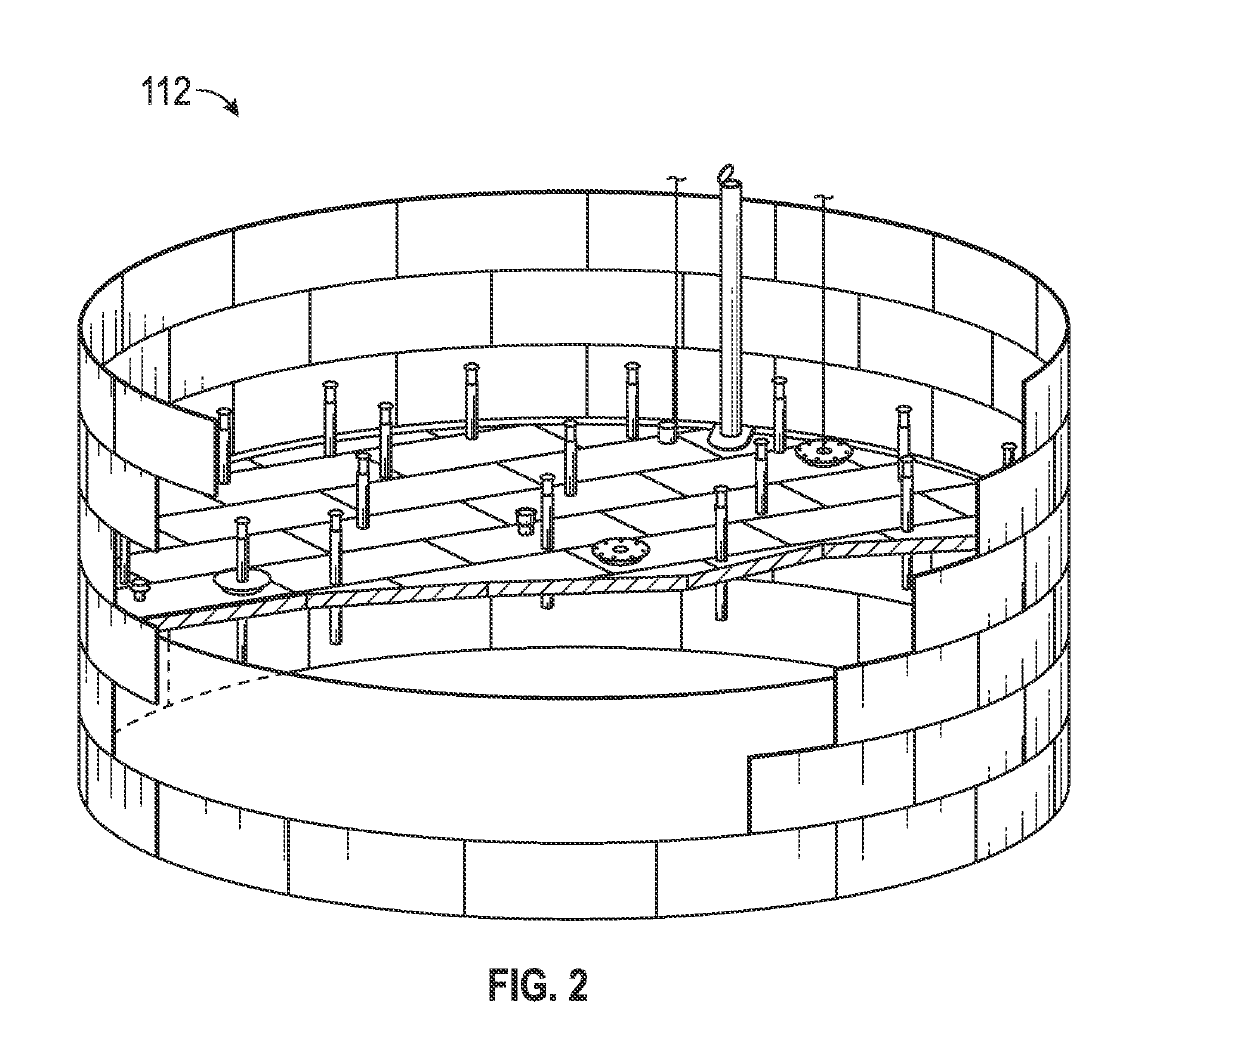
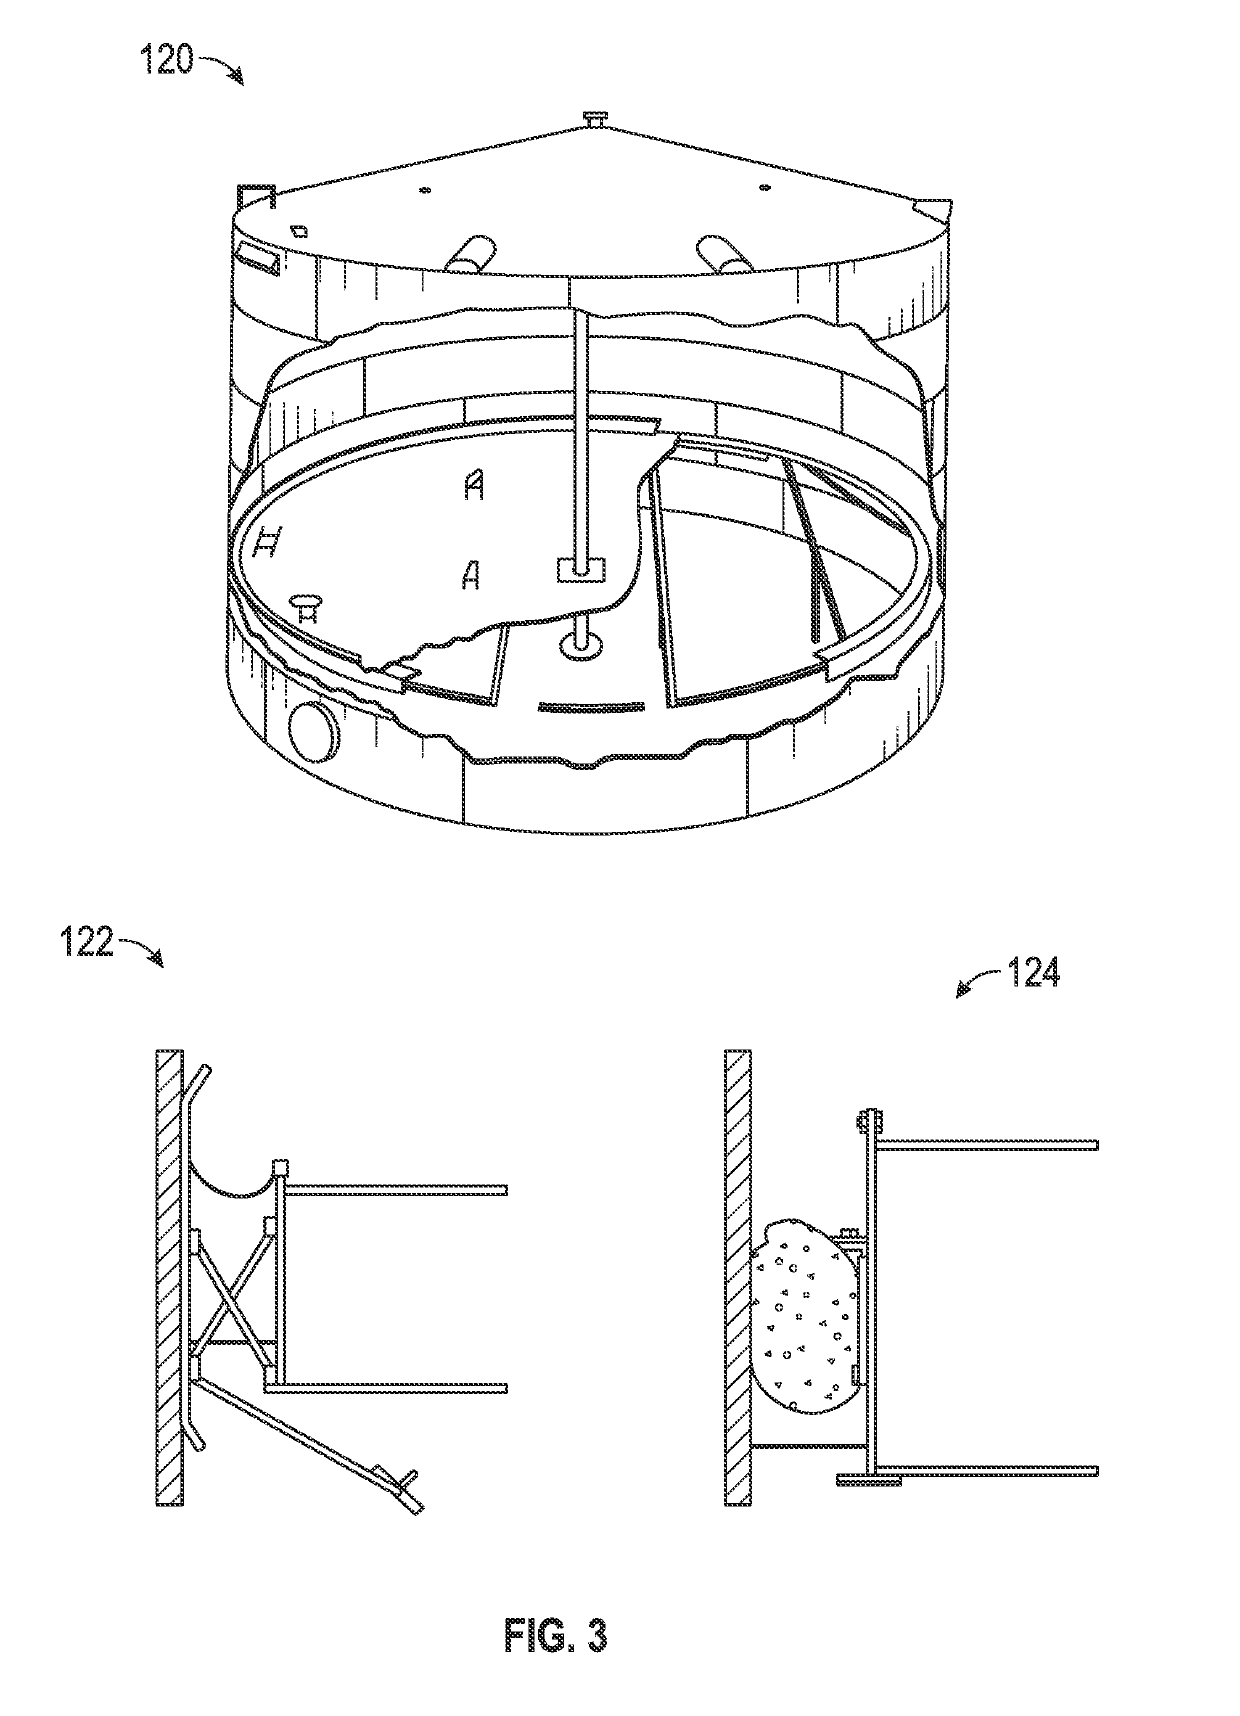
ActiveUS10384866B2Easy to installReduce cablesLarge containersMachines/enginesLaser rangingLevel sensor
A floating roof monitoring system and method. One or more sensors can be disposed atop a liquid storage tank having a floating roof covering liquid stored in the liquid storage tank. Each laser sensor measures the distance between the sensor and the floating roof. One or more liquid level gauges can be deployed, which measure a liquid position of the liquid stored in the liquid storage tank. A computing system communicates electronically with the laser sensor(s) and the liquid level gauge(s) to calculate the difference between the liquid position and the distance between the sensor(s) and the floating roof to determine the exact position of the floating roof and activate an alarm or force a process associated with the liquid storage tank to halt.
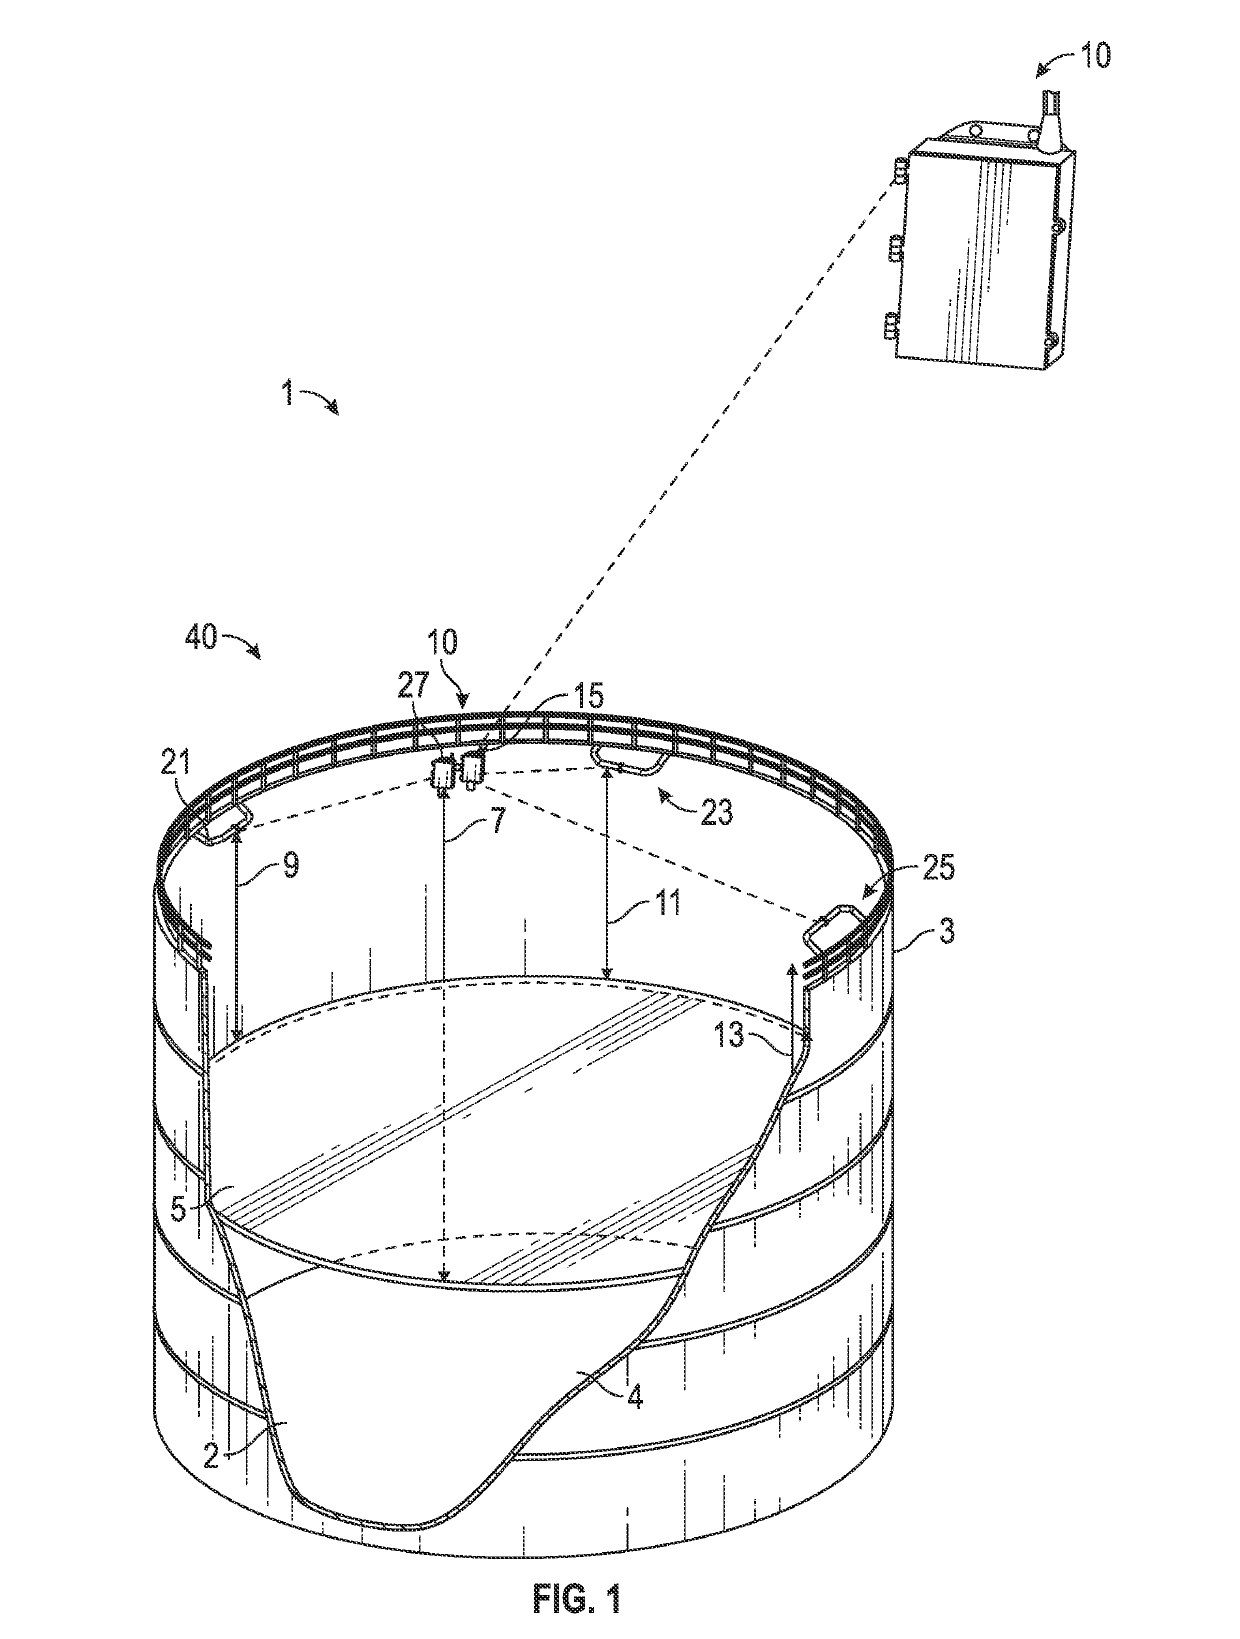
Owner:HONEYWELL INT INC
A SCARA robot
The invention relates to a SCARA robot, comprising a machine base, a first mechanical arm, a second mechanical arm, a transmission mechanism and an actuator, wherein one end of the first mechanical arm is rotatably arranged above the machine base, and the other end is rotatably arranged together with the second mechanical arm; a first driving mechanism, a transmission mechanism and an actuator are arranged on the second mechanical arm, and the transmission mechanism is arranged at the driving end of the first driving mechanism and is drivingly connected with the first driving mechanism; the actuator is arranged at the driving end of the transmission mechanism, and realizes different working states under the driving action of the transmission mechanism, wherein the working states include up and down movement, rotational movement and spiral movement, so that the SCARA robot can drive the actuator on the second mechanical arm to realize the three working states of up and down vertical movement, rotational movement and spiral movement by only one motor, thereby reducing the number of robot connection cables, reducing the difficulty of robot binding, and improving the reliability of the robot.

Owner:GREE ELECTRIC APPLIANCE INC OF ZHUHAI
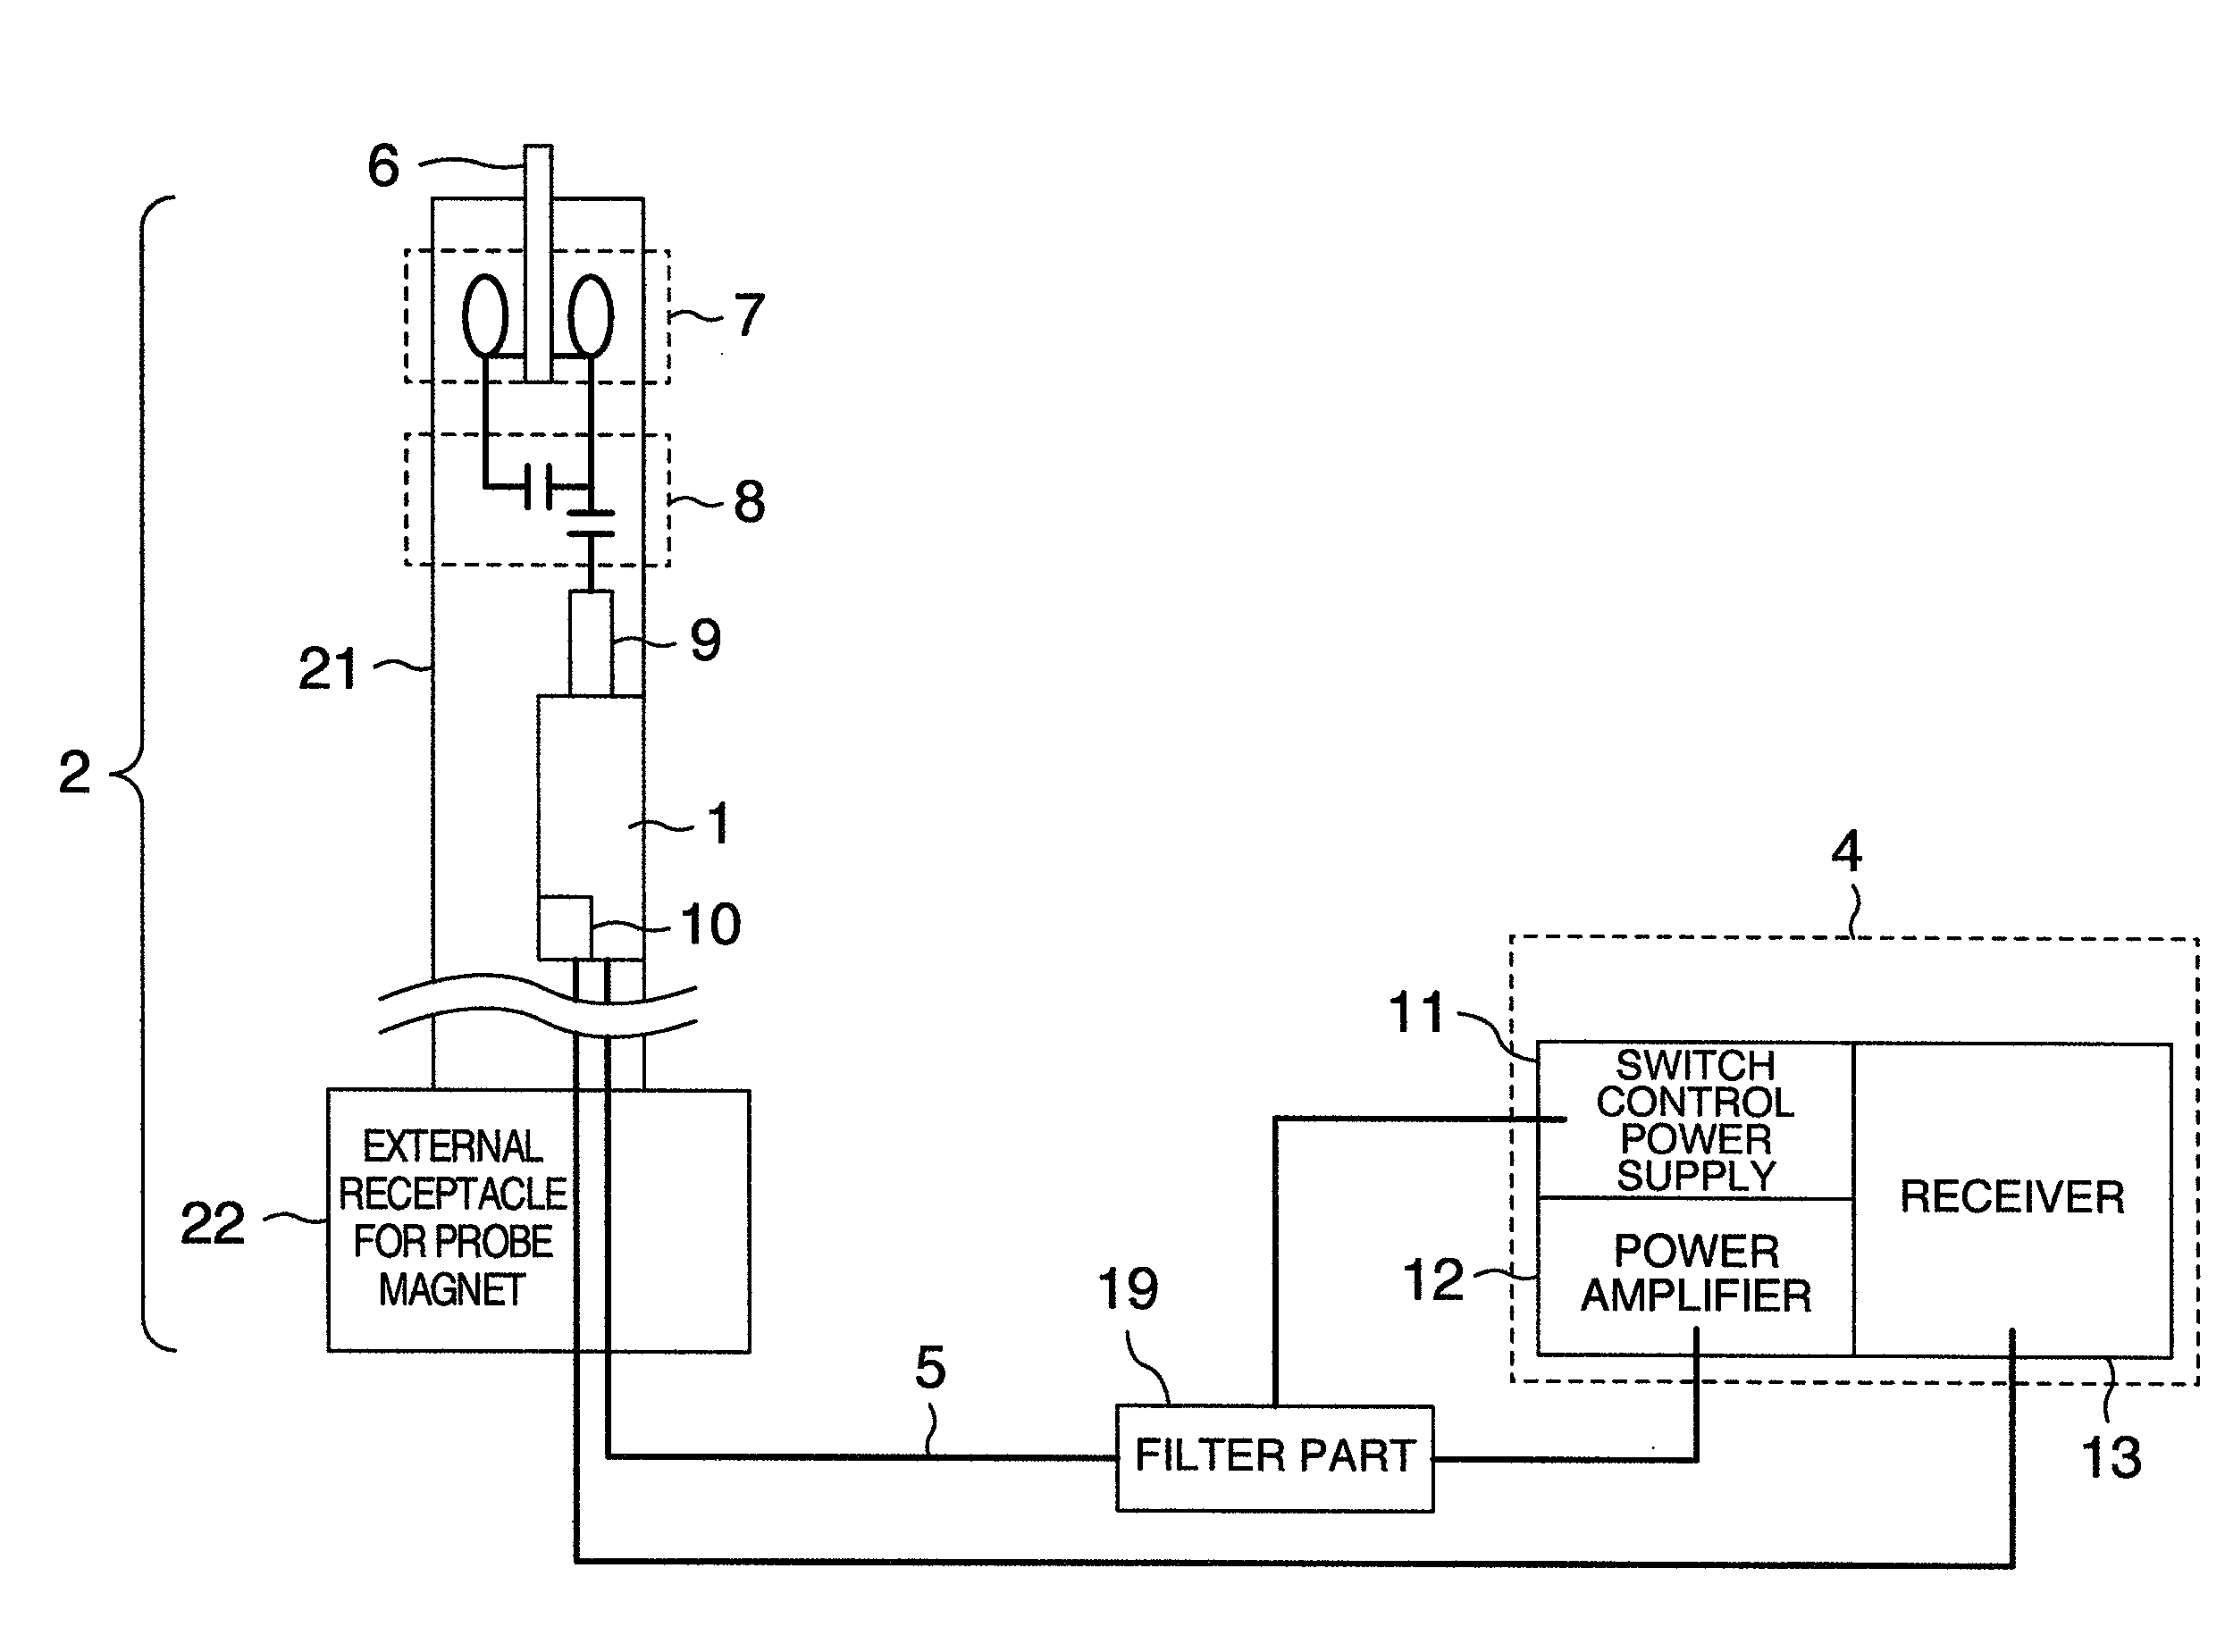
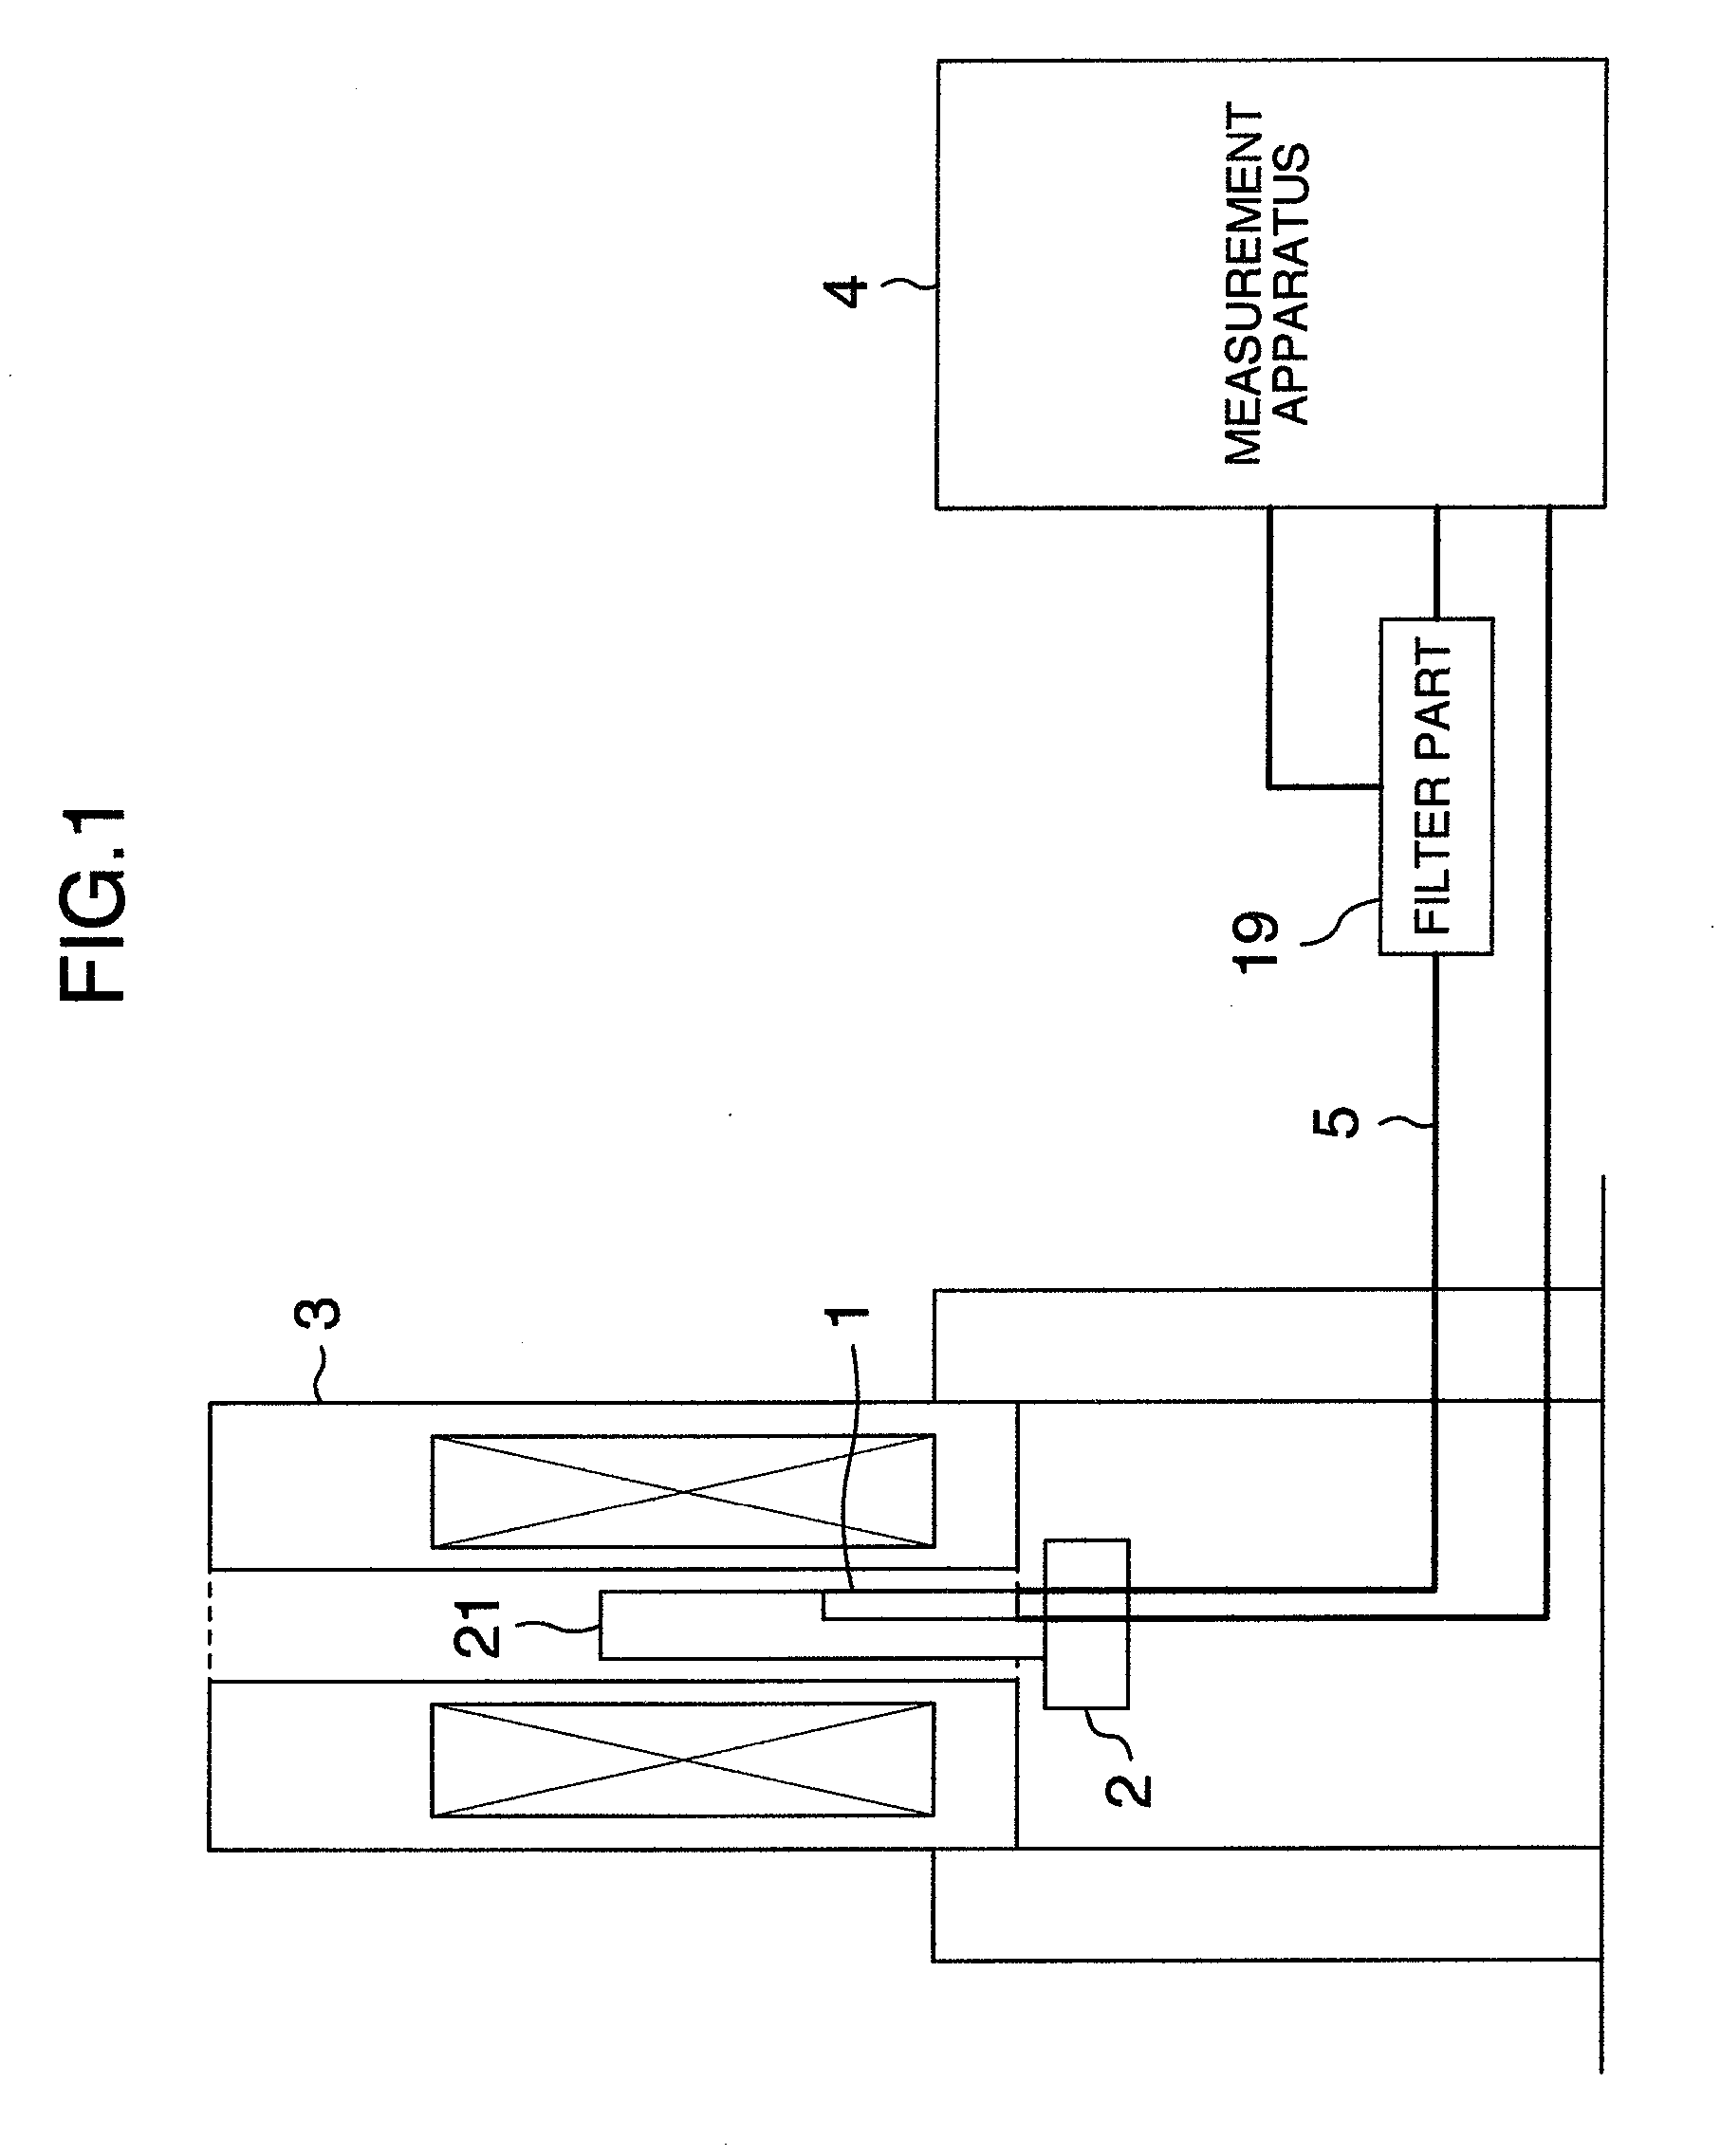
Nuclear magnetic resonance (NMR) probe
InactiveUS20080258730A1Reduction in partHigh sensitivityElectric/magnetic detectionMeasurements using magnetic resonanceNMR - Nuclear magnetic resonanceRf transmission
There is provided a nuclear magnetic resonance probe in which the loss caused by a high frequency cable between a probe coil and a preamplifier is reduced and the sensitivity of an NMR signal is improved. A changeover switch for NMR probe is divided into a switch part including switch elements and a filter part for filtering a switch control signal and an RF transmission signal. The switch part is disposed in a probe body inserted in a magnet of the probe. The filter part is disposed near a measurement apparatus located outside the probe. As for the switch part, a section structure of thickness and width is reduced in conformity with a narrow and slender shape of the probe body. The length of a high frequency cable between the probe coil and the preamplifier is shortened remarkably, and consequently the loss can be reduced.
Owner:HITACHI LTD
Node power supply method and device of multi-node server
InactiveCN109324678ASimple pluggableReduce cablesVolume/mass flow measurementPower supply for data processingModularitySupply & distribution
The invention discloses a node power supply method and device of a multi-node server. The method is applied to a hard disk backplane in the server. The method comprises the following steps that the hard disk backplane can firstly receive a power supply voltage provided by a power supply distribution board; and then, the received power supply voltage can be distributed to each node of the multi-node server. Therefore, the power distribution board is no longer used in the present application to directly unify the distribution power supply for each node of the server, while the power supply voltage provided by the power distribution board is received through the hard disk backplane, and then the power supply is centralized for each node of the multi-node server, thereby meeting the requirement that nodes in some multi-node servers are easy to plug and unplug, and reducing the modular design requirements of cables.


Owner:ZHENGZHOU YUNHAI INFORMATION TECH CO LTD
Interface multiplexing circuit and LED control device
The invention provides an interface multiplexing circuit and an LED control device. The circuit comprises: a dimming signal conversion unit which receives a dimming signal or a half-duplex communication signal from a communication / dimming multiplexing interface; a half-duplex communication unit that shares the communication / dimming multiplexing interface with the dimming signal conversion unit toreceive a dimming signal or the half-duplex communication signal from the multiplexing interface; and a processing unit which is electrically connected with and receives output signals of the dimmingsignal conversion unit and the half-duplex communication unit so as to determine whether the interface multiplexing circuit is in a dimming mode or a communication mode. According to the technical scheme, the same interface not only has a general dimming function, but also has communication and digital dimming functions, cables of input interfaces are effectively reduced, the cost is greatly reduced, the use safety of a lighting system is improved, the application is simpler and more convenient, and the compatibility is better.


Owner:SHANGHAI YAMING LIGHTING
Industrial control system with communication bar and power bar
ActiveUS10908575B2Increase capacityReduce controlProgramme controlComputer controlControl engineeringMechanical engineering
An industrial control system with communication bar and power bar is provided. The industrial control system comprises a plurality of I / O modules; a plurality of terminal boards; at least one communication bar having an input connected with a controller and a plurality of output interfaces, wherein each output interface connects with one I / O module or one terminal board; at least one power bar having an input connected with power supply and a plurality of output interfaces, wherein each output interface connects with one I / O module or one terminal board; wherein each I / O module communicates with one corresponding terminal board through the communication bar respectively.


Owner:ABB (SCHWEIZ) AG
A multi-point real-time acquisition system for environmental data
ActiveCN104267707BImprove real-time performanceReduce overheadMeasurement devicesTotal factory controlMonitoring siteEnvironmental resource management
The present invention provides a multi-point real-time collection system for environmental data, including: a host computer and one or more lower computers distributed in different areas, each lower computer includes a micro-control unit and a plurality of monitors deployed at different monitoring points in the corresponding area Sensor; the sensor is used to collect the environmental data of the monitoring point; the micro-control unit is used to obtain the environmental data of each monitoring point in real time; judge whether the current environmental data of each monitoring point obtained in real time has changed drastically, and will The current environmental data and the identity information of corresponding monitoring points are transmitted to the upper computer; the upper computer is used to receive the environmental data and the identity information of corresponding monitoring points sent by each lower computer in real time, and for any monitoring point, if the upper computer does not When the new data of the monitoring point is received, the current environmental data of the monitoring point is by default consistent with the data received last time. The invention can improve the real-time performance of environment data summarization and tracking with lower overhead.


Owner:INST OF COMPUTING TECH CHINESE ACAD OF SCI
Special telephone for set-top box
InactiveCN102946452AReduce cablesReduce the number of interfacesTelephone set constructionsTelecommunicationsCommunication quality
The invention discloses a special telephone for a set-top box. The special telephone comprises a common telephone, a voice conversion module, a cable and a standard interface, wherein the voice conversion module is used for converting audio and control signals into two-line public switched telephone network (PSTN) signals; the cable is directly connected with the voice conversion module; and the standard interface is formed at the other end of a cable body and is used for being connected with the set-top box. According to the embodiment of the invention, the special telephone is manufactured by adding the voice conversion module on the common telephone and is provided with one cable, so the cables and the interfaces between the set-top box and the telephone are reduced, the cost is reduced, and the communication quality and the using convenience are improved at the same time.

Owner:NUBIA TECHNOLOGY CO LTD