
Patents
Literature
35results about How to "Simplify the planning process" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Multidimensional collaborative power grid planning method
InactiveCN103116865AImprove convenienceHigh feasibilityData processing applicationsInformation technology support systemPower gridCost calculation
The invention discloses a multidimensional collaborative power grid planning method which includes the processes: acquiring geographic environmental information data and calculating comprehensive construction cost data by a rasterized map; building a power grid planning model; and calculating the solution of a power grid planning scheme by an optimal ant colony algorithm according to the acquired data and the power grid planning model. The method includes the steps: comprehensively considering substation locating and sizing, line selection and line corridor selection; and building a multidimensional collaborative power grid planning model considering complicated environmental influence. The multidimensional collaborative power grid planning method can accurately consider the influence of environmental factors on power grid planning. Line construction cost calculation precision is improved, and estimation difficulty is reduced. Catalytic elements are generated according to deviation of the local movement direction and the target movement direction of ants, so that the state transition rule of the ants is improved. The construction cost of lines on a mass raster and a substation is full-automatically and rapidly calculated, and calculation precision and efficiency are remarkably improved.


Owner:NORTH CHINA ELECTRIC POWER UNIV (BAODING)
Gait generation and optimization method for biped robot
ActiveCN110315543AReduce energy lossAvoid errorsProgramme-controlled manipulatorVehiclesSimulationState switching
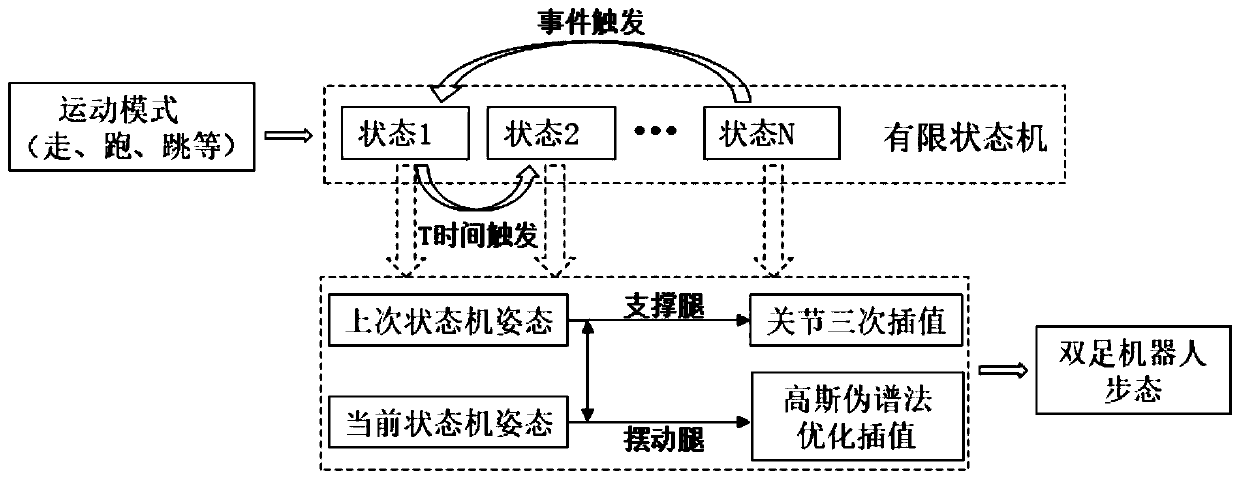
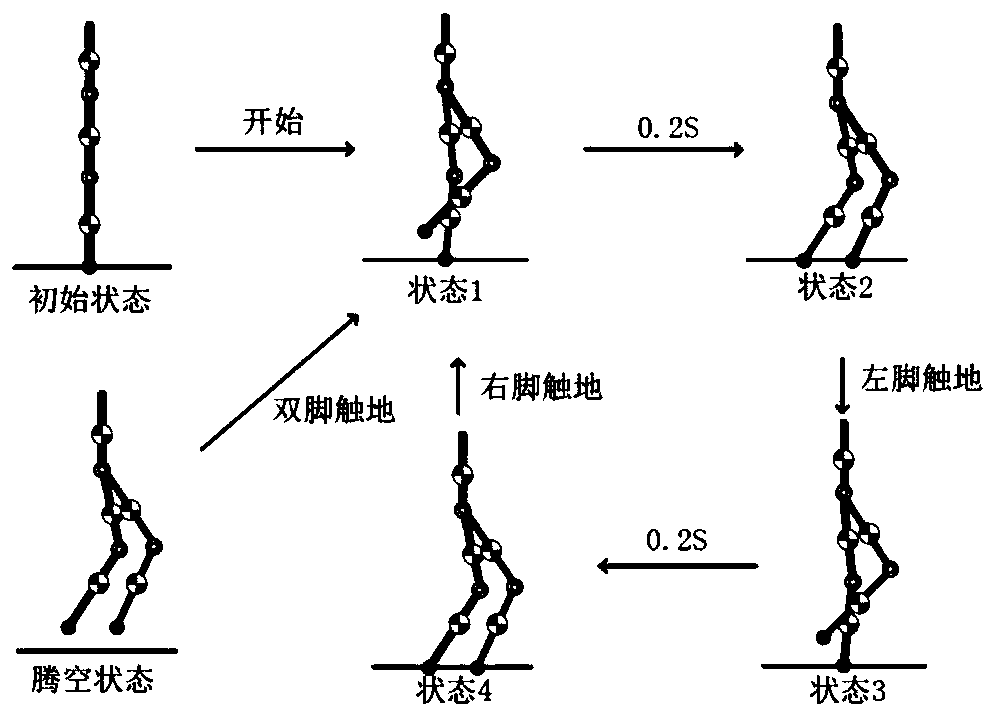
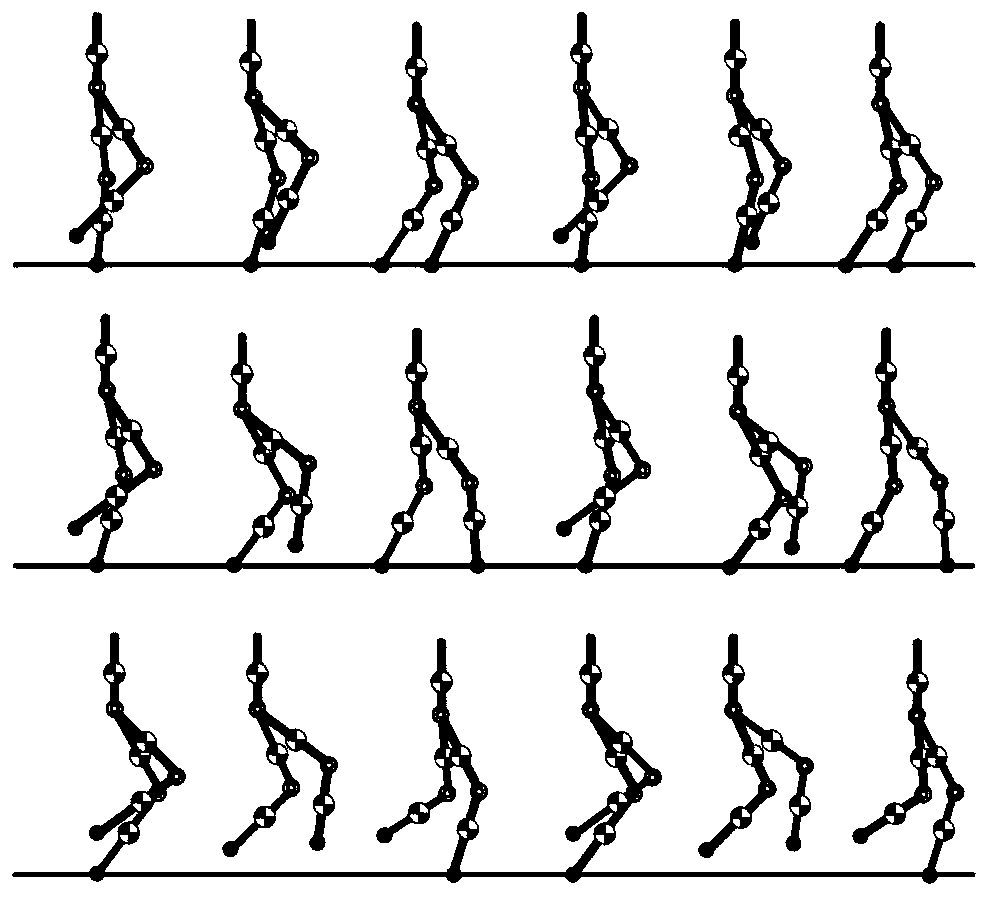
The invention discloses a gait generation and optimization method for a biped robot. The method is characterized in that a gait library of the biped robot is constructed in a finite state machine according to a target pose of the state of the biped robot; mutual switching conditions among all states of the robot are set and triggered; in each state switching process, a joint cubic interpolation method is used for planning the movement track of support legs, and a gauss pseudo-spectral method is used for optimizing the movement track of swing legs; and finally, the gait of the biped robot in different motion modes is generated by the finite state machine. According to the gait generation and optimization method for the biped robot, the constraint of ZMP is not considered, and all the bipedrobots with or without the sole edges of the feet can generate the walking track by the method; and the planning process is simple and operable and is more suitable for online generation, and the biped walking robot can stably walk and finish walking, running, jumping and other actions by matching with a simple control strategy.
Owner:BEIJING INSTITUTE OF TECHNOLOGYGY
Demand response type bus scheduling method
ActiveCN111105141AImprove economyQuick and easyInternal combustion piston enginesResourcesTransit busDistributed computing
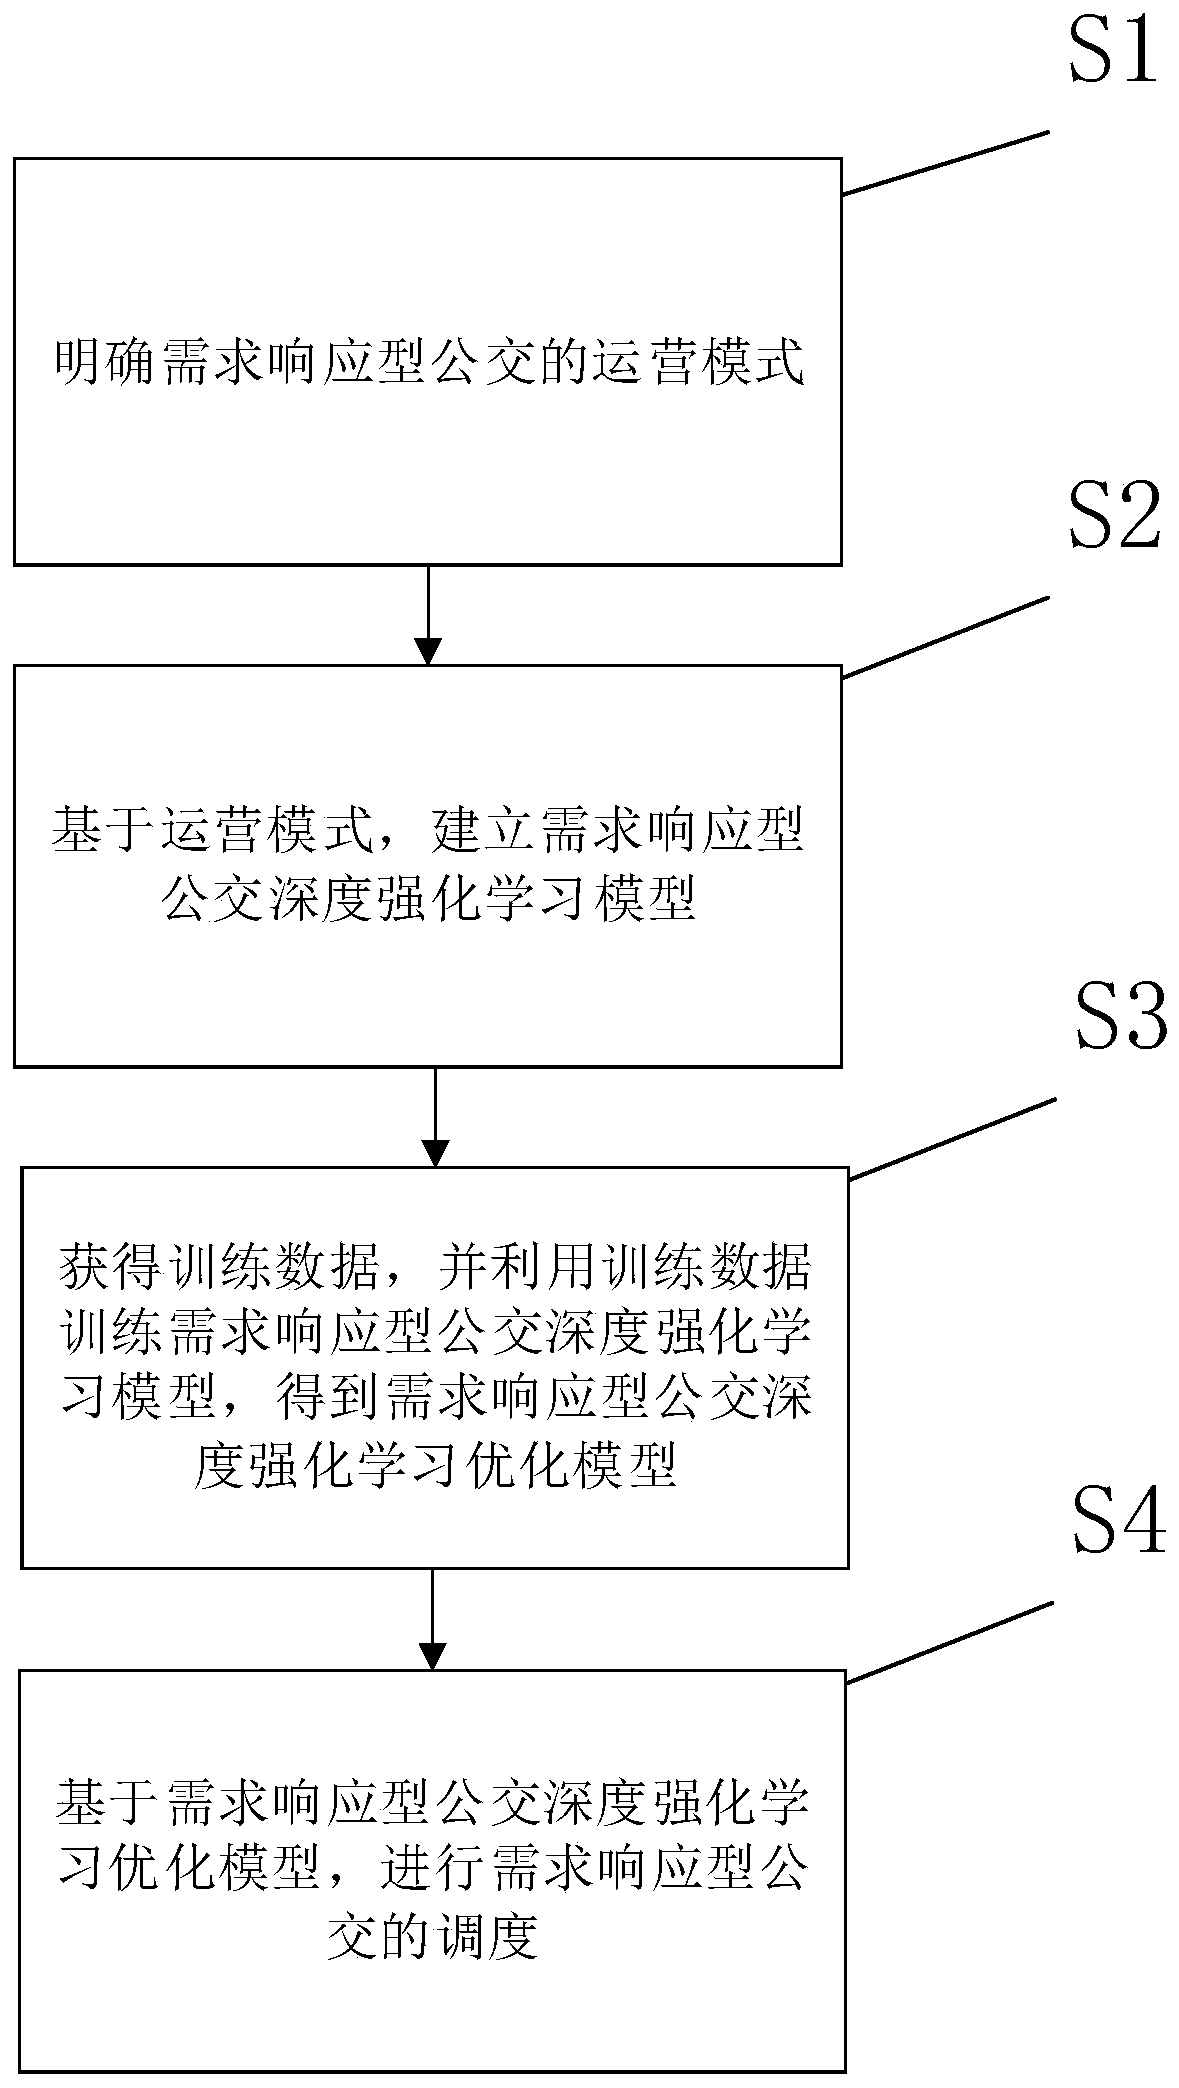
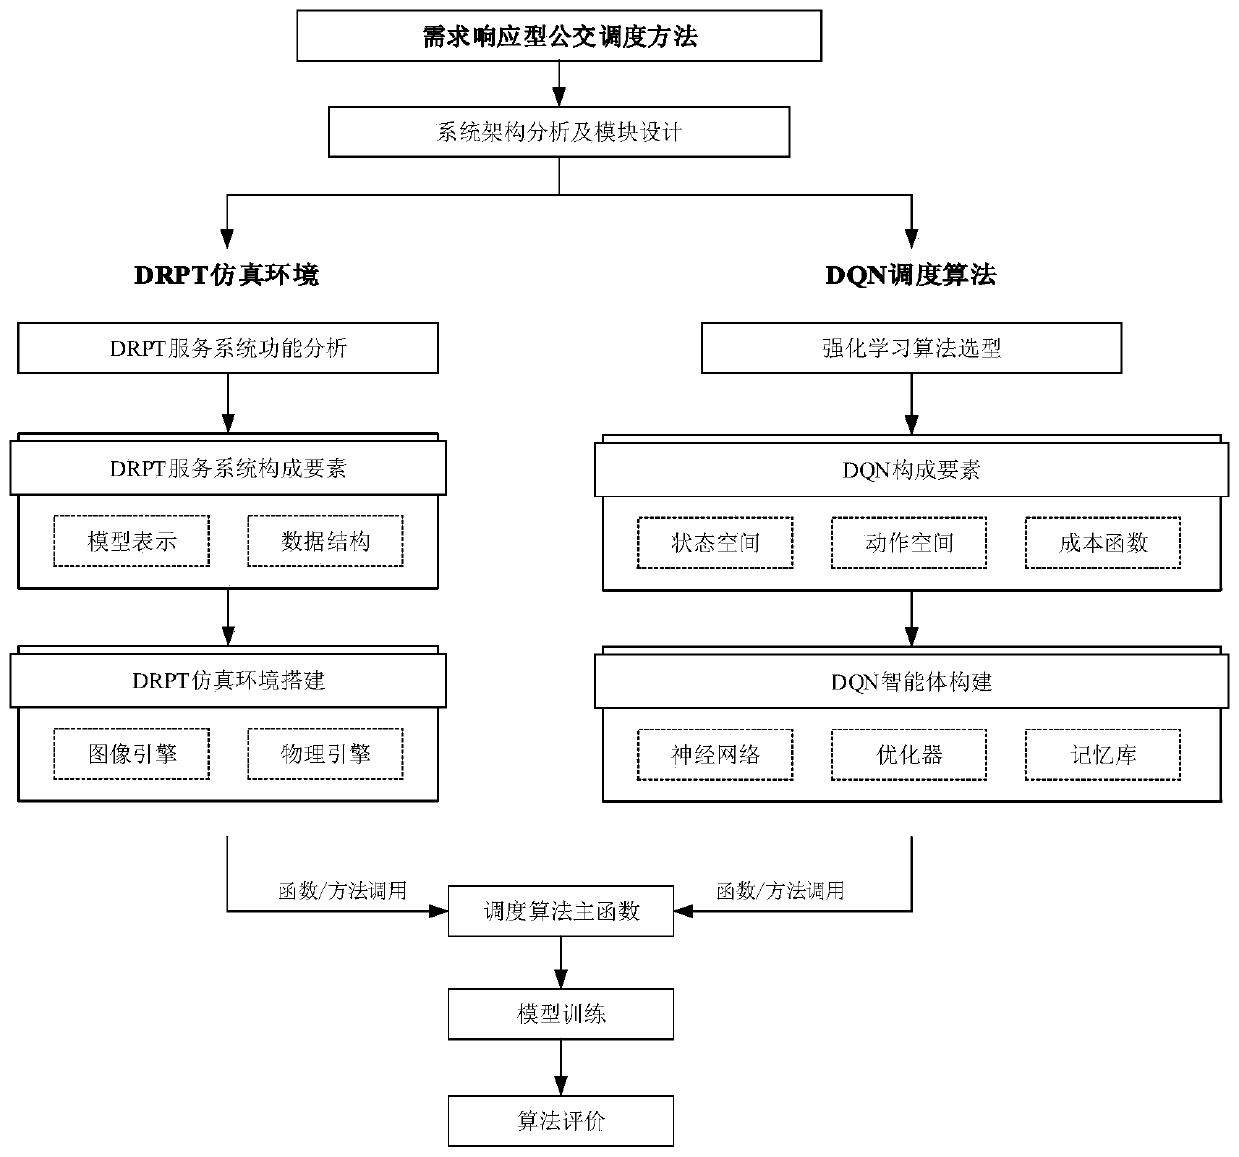
The invention relates to a demand response type bus scheduling method. The method comprises the following steps: S1, defining an operation mode of a demand response type bus; S2, based on the operation mode, establishing a demand response type bus deep reinforcement learning model; S3, obtaining training data, and training the demand response type bus deep reinforcement learning model by using thetraining data to obtain a demand response type bus deep reinforcement learning optimization model; and S4, scheduling the demand response type bus based on the demand response type bus deep reinforcement learning optimization model. Compared with the prior art, the modeling and solving process is simple, and the model is easy to migrate and generalize.
Owner:TONGJI UNIV
Common pilot frequency hopping method in LTE system
InactiveCN101621325ASimplify the planning processAvoid collisionRadio transmission for post communicationOrthogonal multiplexEngineeringElectrical and Electronics engineering
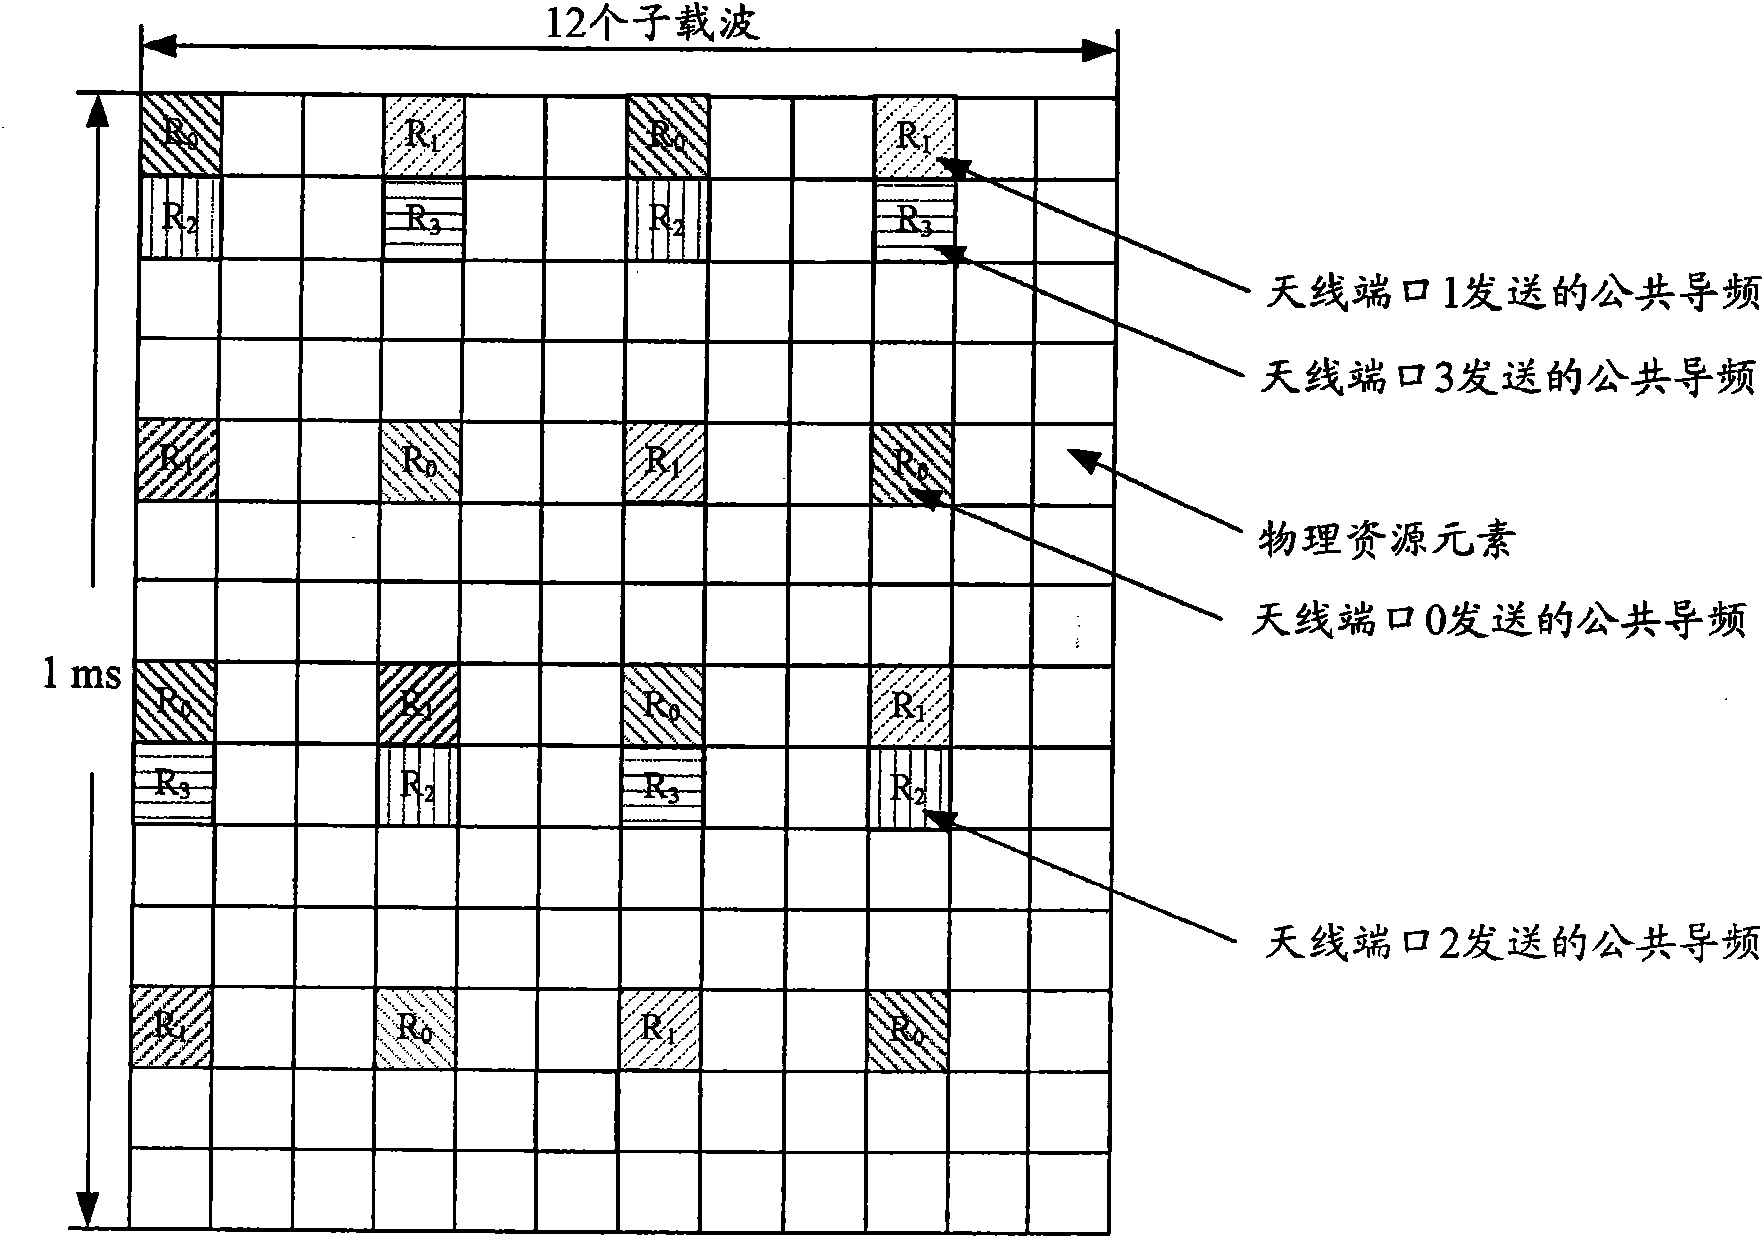
The invention relates to a common pilot frequency hopping method in an LTE system, including that frequency hopping offset is limited to be within the minimum of resource units located between two common pilot frequencies on the same orthogonal frequency divided multiplex OFDM symbol when a base station is in frequency hopping on each downlink common pilot frequency of a cell. The frequency hopping method of the invention can avoid collision of common pilot frequencies on different antenna ports of adjacent cells, so that channel estimation of the common pilot frequency obtains more stable frequency hopping gain.
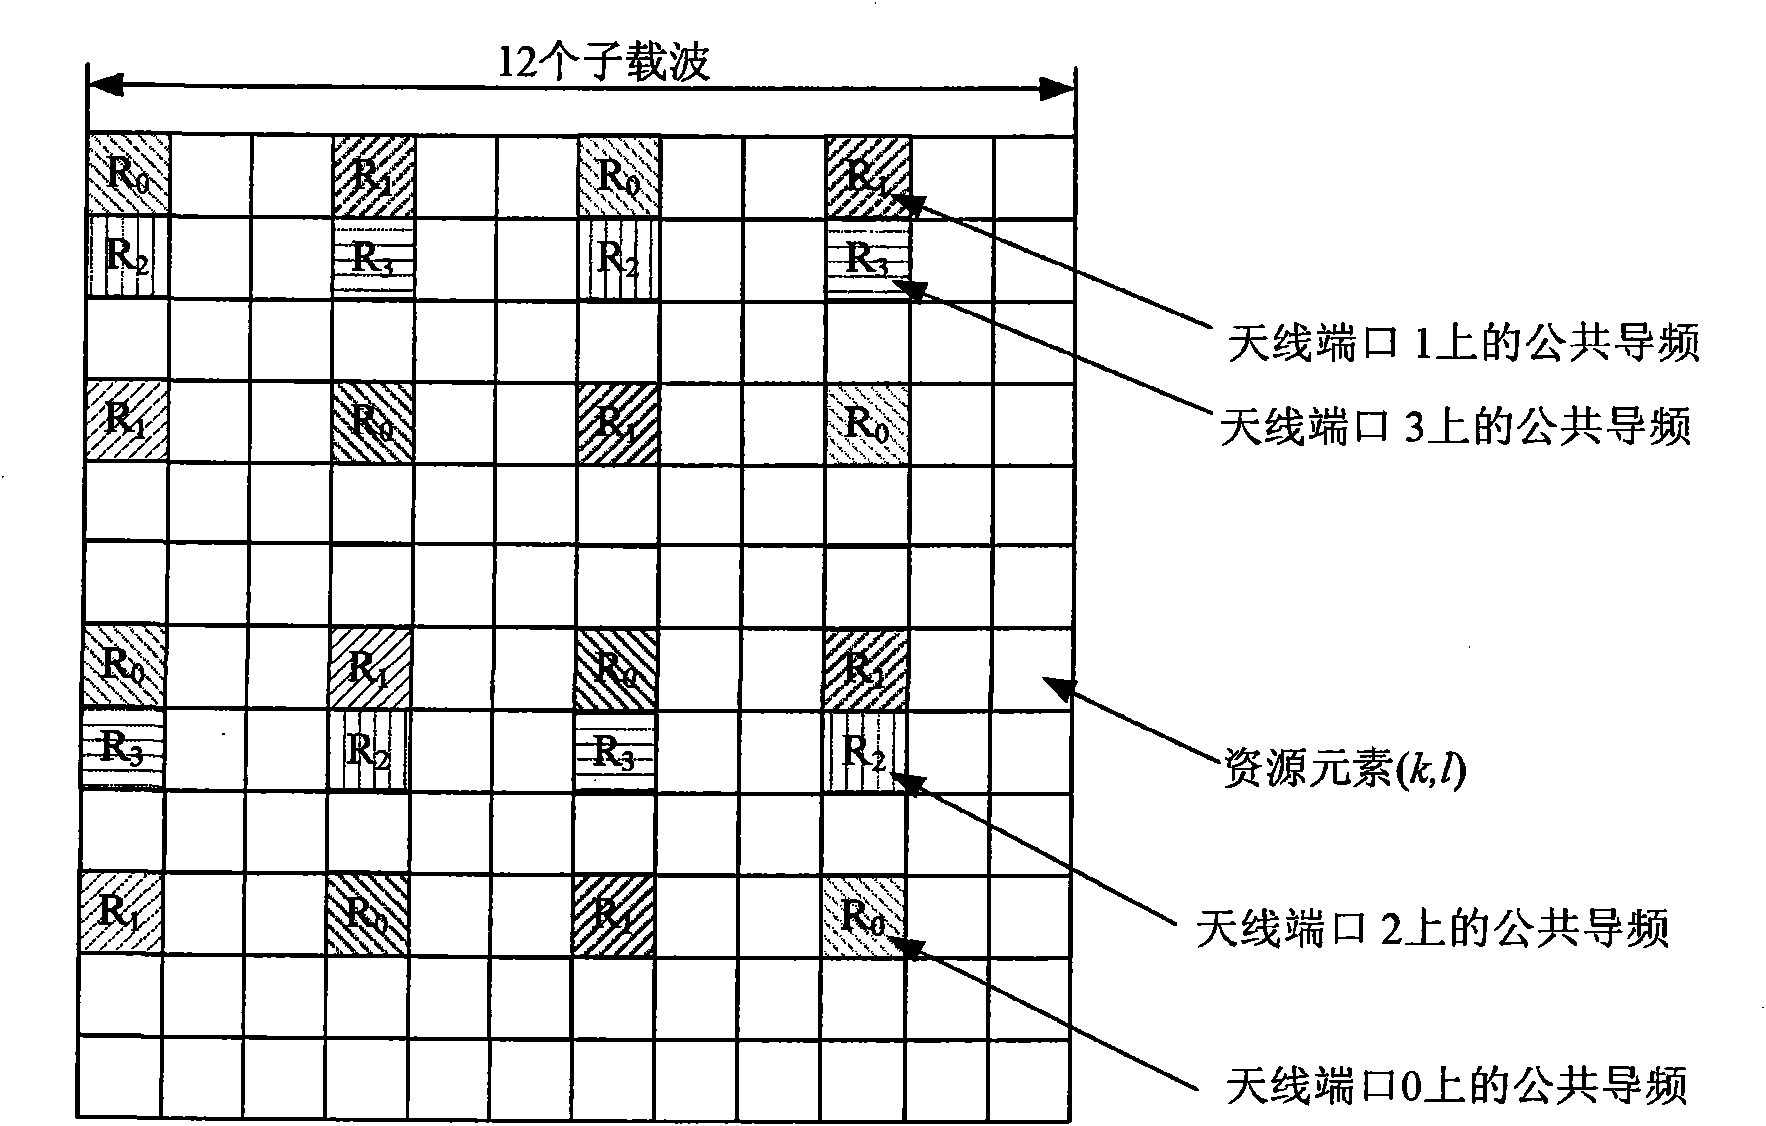
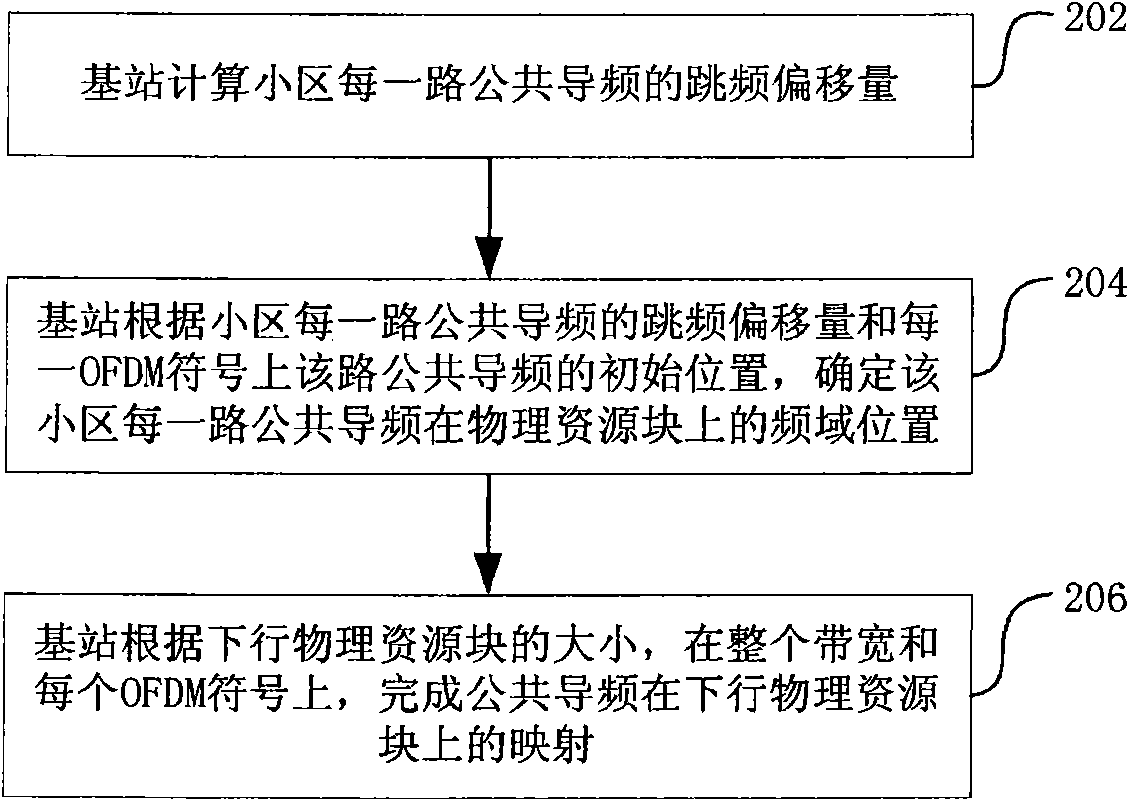
Owner:ZTE CORP
Advanced plan optimal management auxiliary system
InactiveCN101673360AImprove network efficiencySimplify the planning processForecastingSpecific program execution arrangementsOptimal managementSystems engineering
The invention relates to the field of auxiliary systems of management systems, in particular to an auxiliary system of an advanced plan optimal management. The system comprises stock of supplier management; collaborative planning, forecasting and supplying; collaborative supply management; transportation management; direct acquisition; production planning; performance management; and design for success. The system ensures that a supply chain APO can be easily integrated with a supply chain execution system to enable a user to better apply the APO planning function, including an enterprise system and production transportation plan application. Therefore, the user can establish a closed circulating circuit to greatly improve the network functions, and a planning mode for turning a periodic plan to event driven. The user can easily links supply chain management with a non SAP system and other solutions, for example, the supply chain management can be integrated with client relationship management together to verify the usability of a purchased product, simplify the planning process of a promotion activity, and realize synchronization of supply chain running and client requirement.
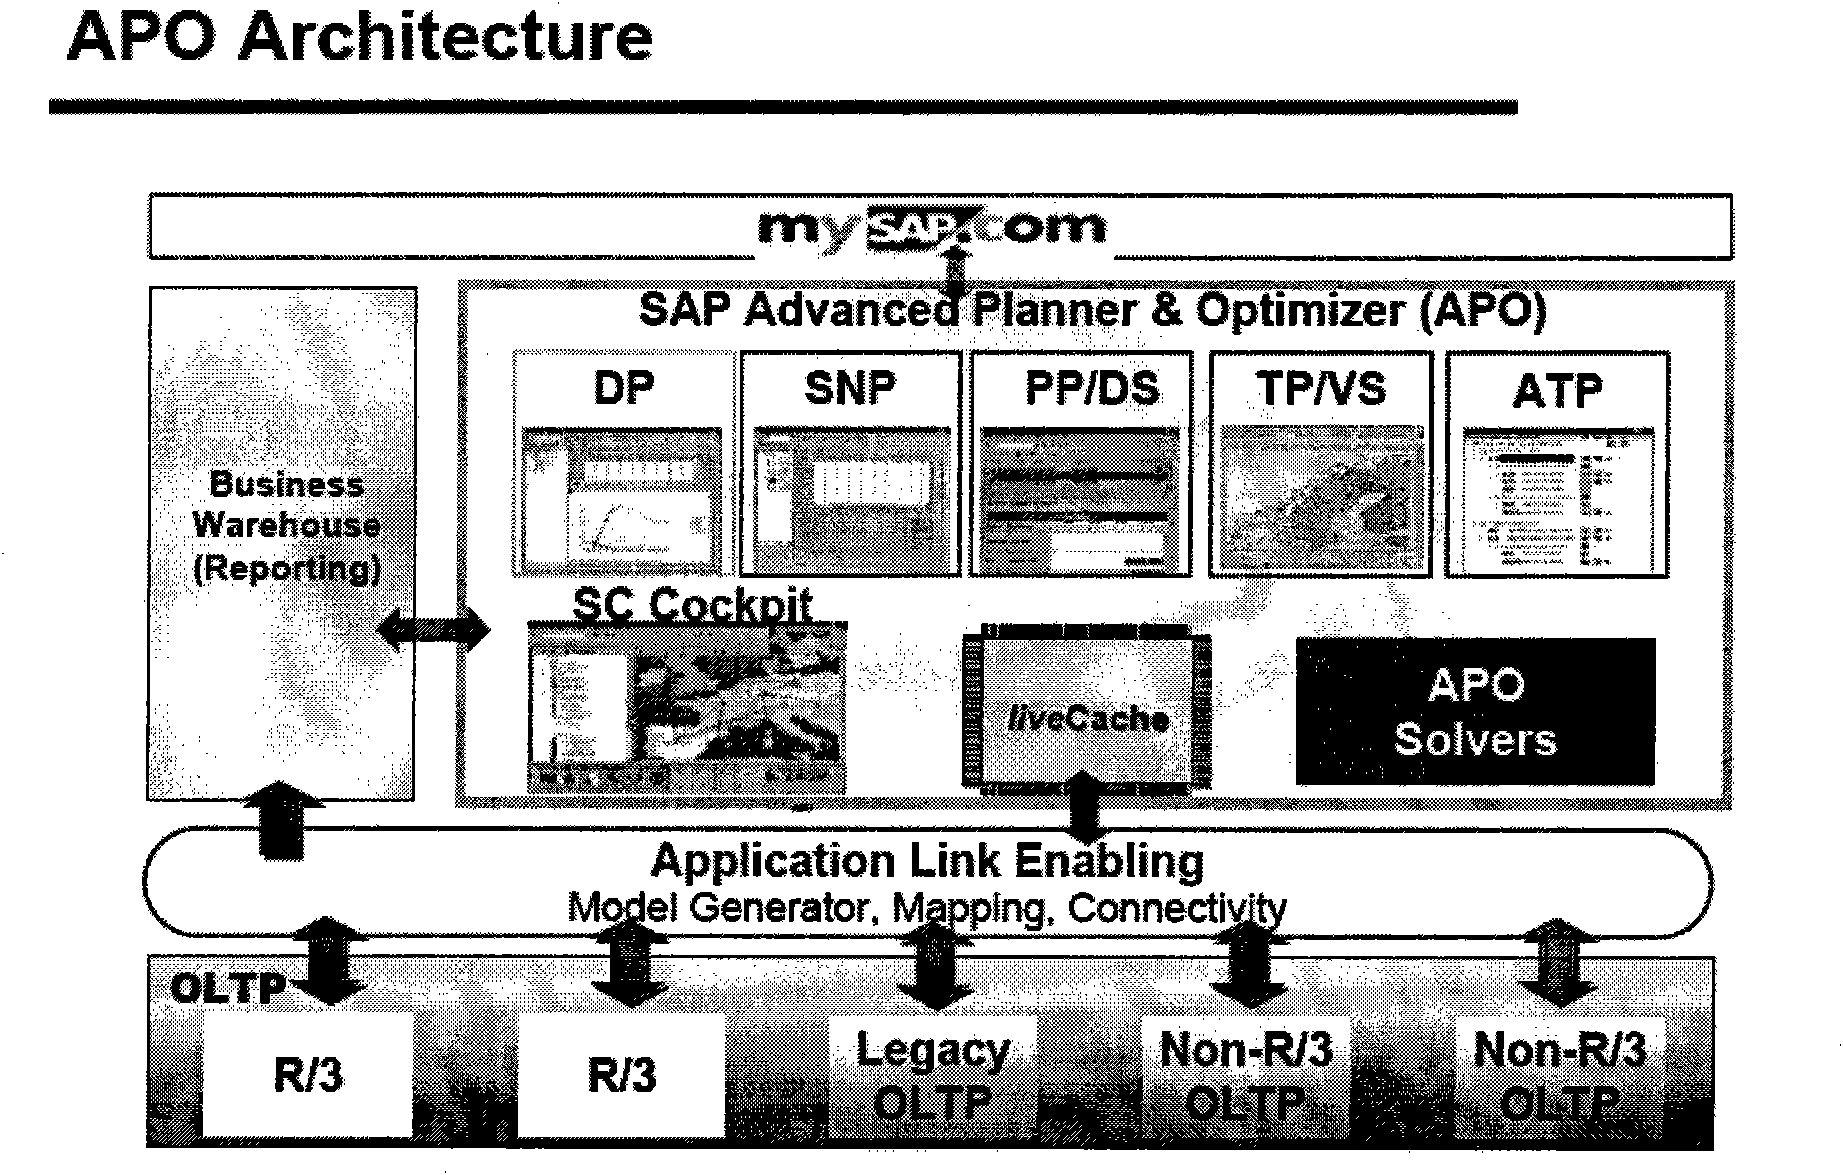
Owner:BEIJING ZHENGCHEN SCI & TECH DEV
Formation unmanned aerial vehicle multi-angle strike flight path planning method based on grid planning algorithm
ActiveCN112327927ASimplify the planning processImprove planning efficiencyPosition/course control in three dimensionsSimulationUncrewed vehicle
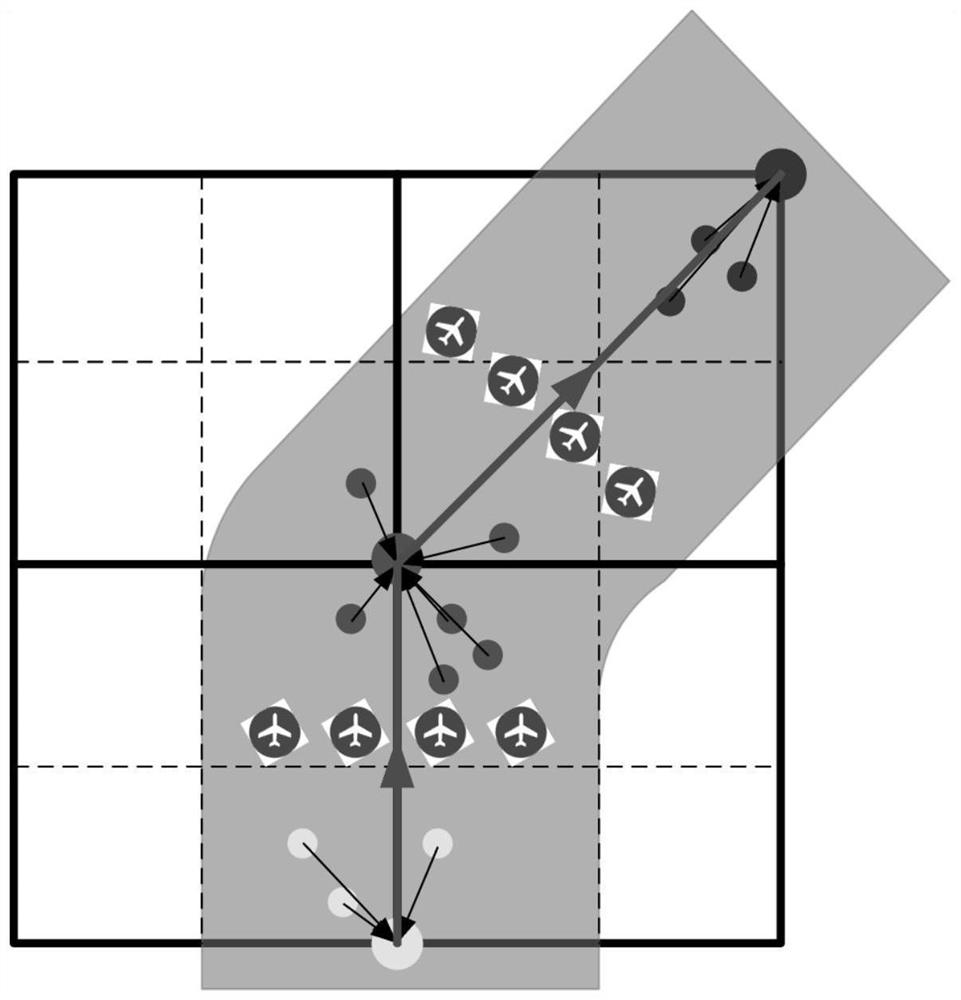
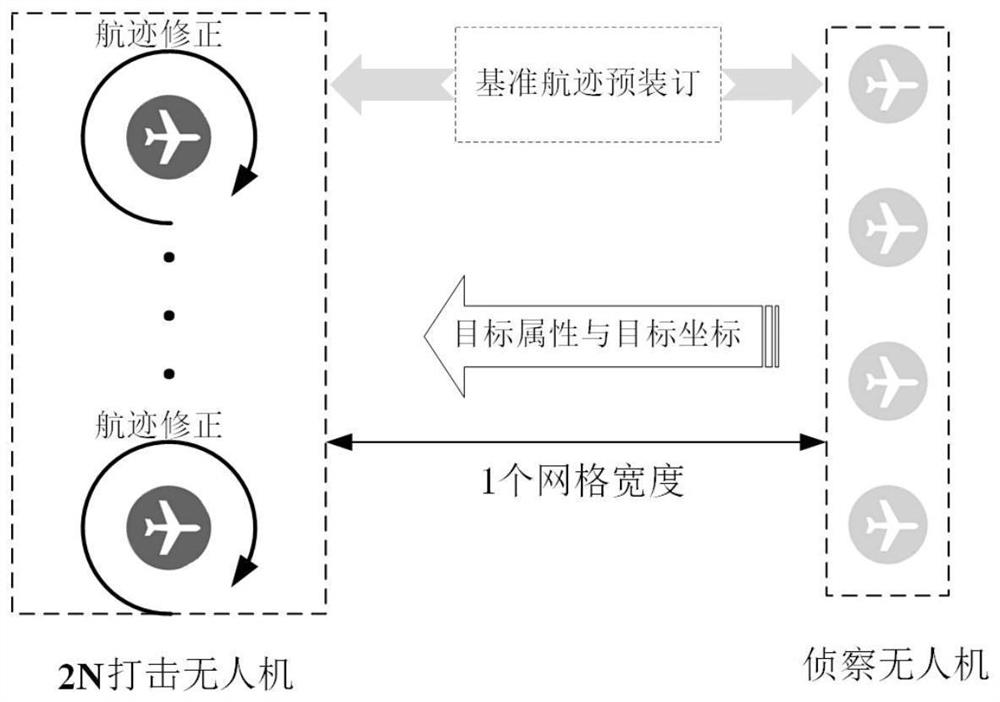
The invention discloses a formation unmanned aerial vehicle multi-angle strike flight path planning method based on a grid planning algorithm, and belongs to the technical field of flight path autonomous planning. The implementation method comprises the following steps of: explaining and modeling a scene and a problem which need to be planned, designing unmanned aerial vehicle formation members and formation forms, and formulating multi-angle striking schemes of targets with different values; performing position integration on a plurality of suspected targets, performing reconnaissance confirmation, and performing planning based on the grid planning algorithm to obtain flight paths of reconnaissance unmanned aerial vehicles in a formation; and expanding a planning result according to the value information of the targets to obtain a multi-angle strike flight path of the unmanned aerial vehicle formation. According to the method, rapid planning of the multi-angle strike flight path of the formation unmanned aerial vehicles is achieved based on the grid planning algorithm, the autonomous multi-angle strike flight path planning efficiency of the formation unmanned aerial vehicles can be improved, the formation unmanned aerial vehicles can execute multi-angle strike of different schemes on targets with different values; and the method has the advantages of being reliable in flight path point and easy to operate.
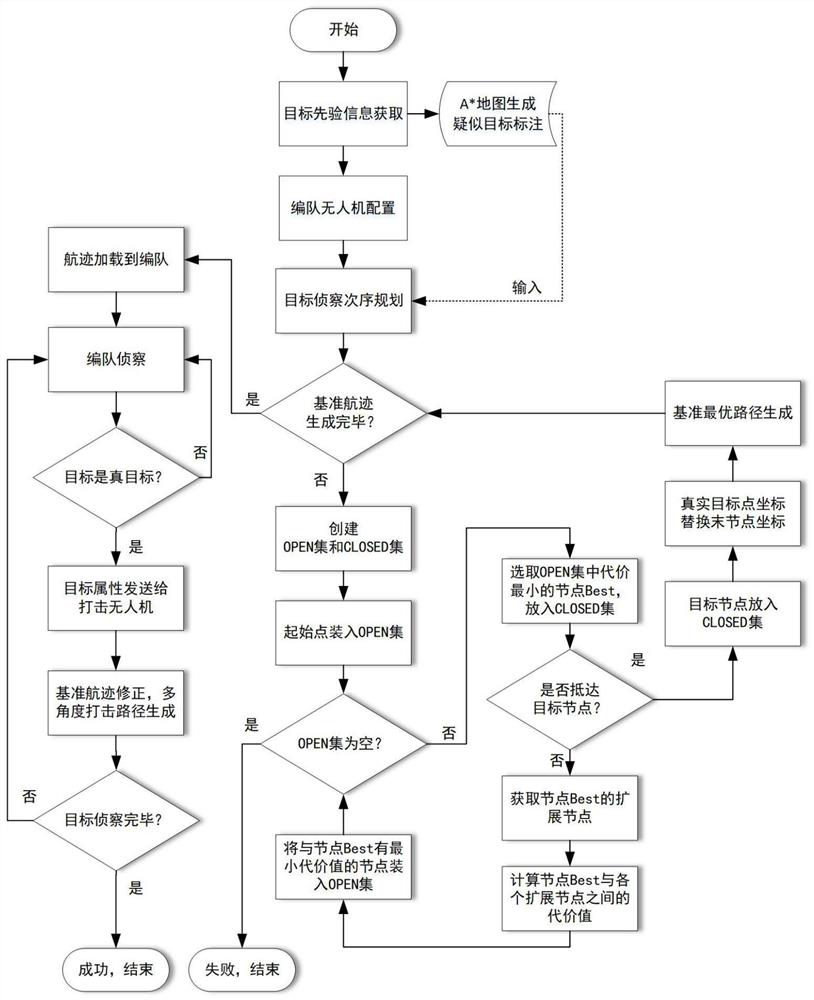
Owner:BEIJING INSTITUTE OF TECHNOLOGYGY
Inspection robot global path planning method based on three-dimensional grid map
PendingCN119573760AImprove the effect of obstacle avoidanceincrease flexibilityInstruments for road network navigationPoint cloudComputer graphics (images)
The invention relates to an inspection robot global path planning method based on a three-dimensional grid map. The method comprises the following steps: constructing a three-dimensional point cloud map; constructing a three-dimensional occupation grid map; calculating the height difference between each grid and an adjacent grid of the three-dimensional occupied grid map, and marking the current grid and continuous grids in the vertical direction, namely the z direction, as grids with the same attribute; giving current position and target point position information of the robot, and converting the information into serial numbers to which grids belong; and traversing surrounding grids from a starting point by using an A * algorithm until a target point position is searched, and forming a global path from the starting point to the target point. According to the invention, a traditional two-dimensional grid map is replaced by a three-dimensional grid map, so that the obstacle avoidance capability of the ground mobile robot in a complex terrain is remarkably improved, the flexibility of the robot is improved, the safety of the robot in an actual application scene is enhanced, and especially in a dynamically changing environment, the obstacle avoidance capability of the robot is greatly improved. The path can be adjusted in time to avoid collision.


Owner:STATE GRID ANHUI ELECTRIC POWER CO LTD JINZHAI COUNTY POWER SUPPLY CO
Improved unmanned aerial vehicle route planning method based on artificial potential field method
InactiveCN113534838AEnsure safetySimplify the planning processPosition/course control in three dimensionsUncrewed vehicleControl theory
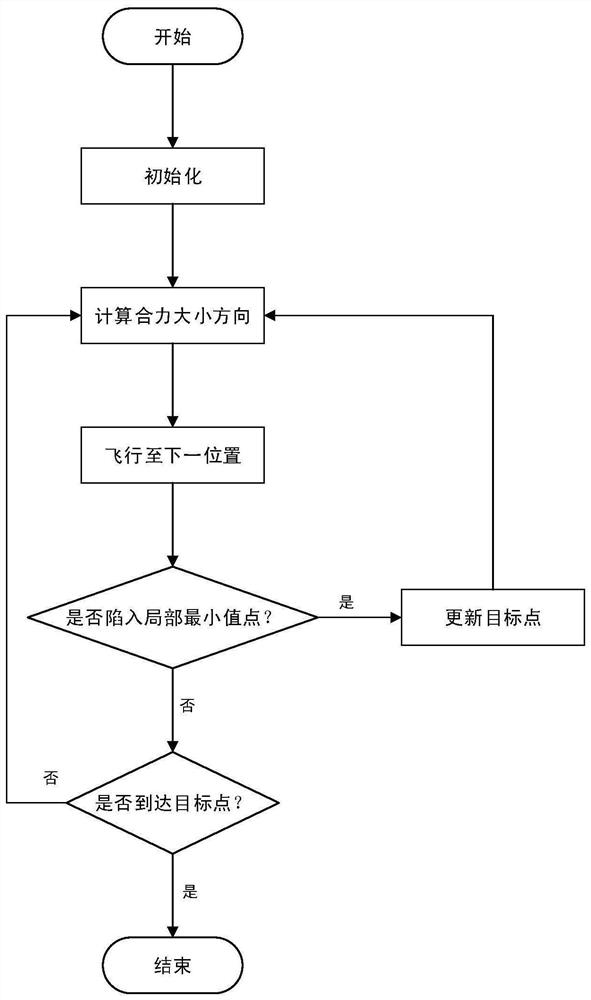
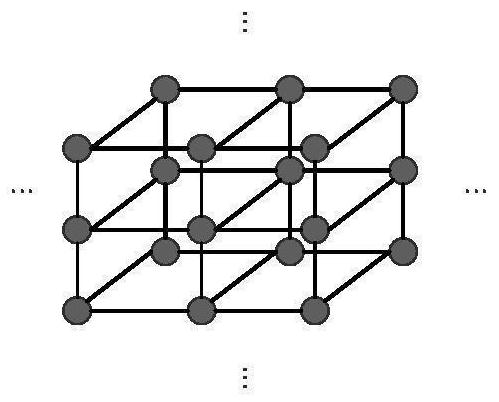
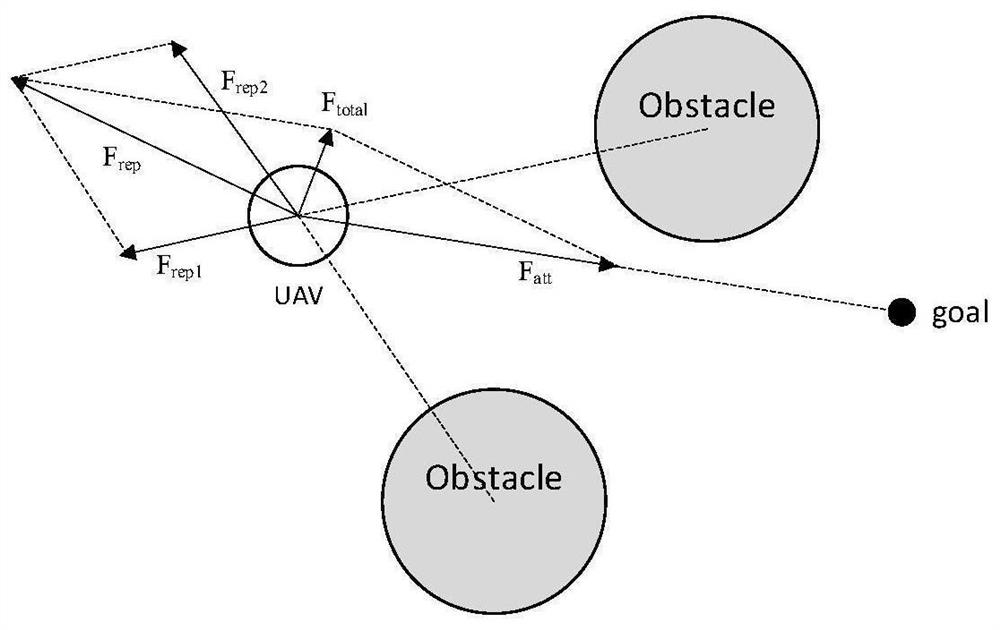
The invention relates to an improved unmanned aerial vehicle route planning method based on an artificial potential field method, and belongs to the field of unmanned aerial vehicle route planning. Firstly, modeling is carried out on a three-dimensional terrain and forest environment space, that is, an external environment is divided into a gravitational field area and a repulsion field area, a gravitational field is established with a target point as the center, a repulsion field is established with an obstacle as the center, it is guaranteed that the target point is a global minimum point of a combined potential field, and therefore an unmanned aerial vehicle can reach the target point in the descending direction of the combined potential field. Then, the resultant force borne by the unmanned aerial vehicle at the current moment is calculated in real time through the potential field intensity of the current position, and the unmanned aerial vehicle advances towards the target point under the combined action of the target gravitational field of the unmanned aerial vehicle and the repulsion field around the obstacle. Meanwhile, whether the unmanned aerial vehicle is trapped in the local point is judged, and if yes, the unmanned aerial vehicle jumps out of the local minimum point through a method of updating the sub-target points in time. Finally, the unmanned aerial vehicle arrives at the target point along the optimal path. The method is higher in calculation efficiency and higher in safety.
Owner:NORTHWESTERN POLYTECHNICAL UNIV
Urban rail transit elevated line planning method and device based on acoustic environment
ActiveCN110458475ASimplify the planning processImprove work efficiencySubsonic/sonic/ultrasonic wave measurementResourcesNoise correctionEngineering
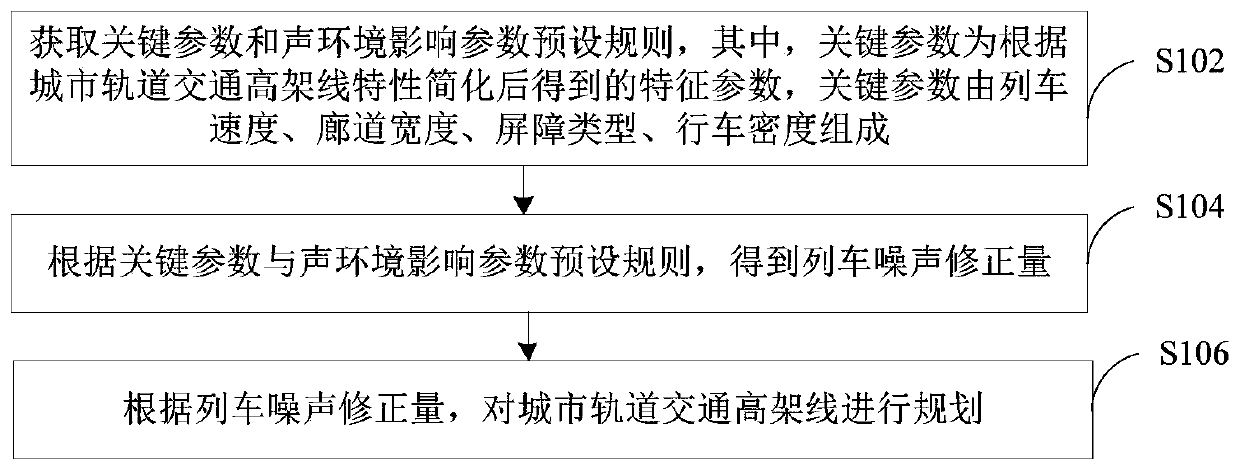
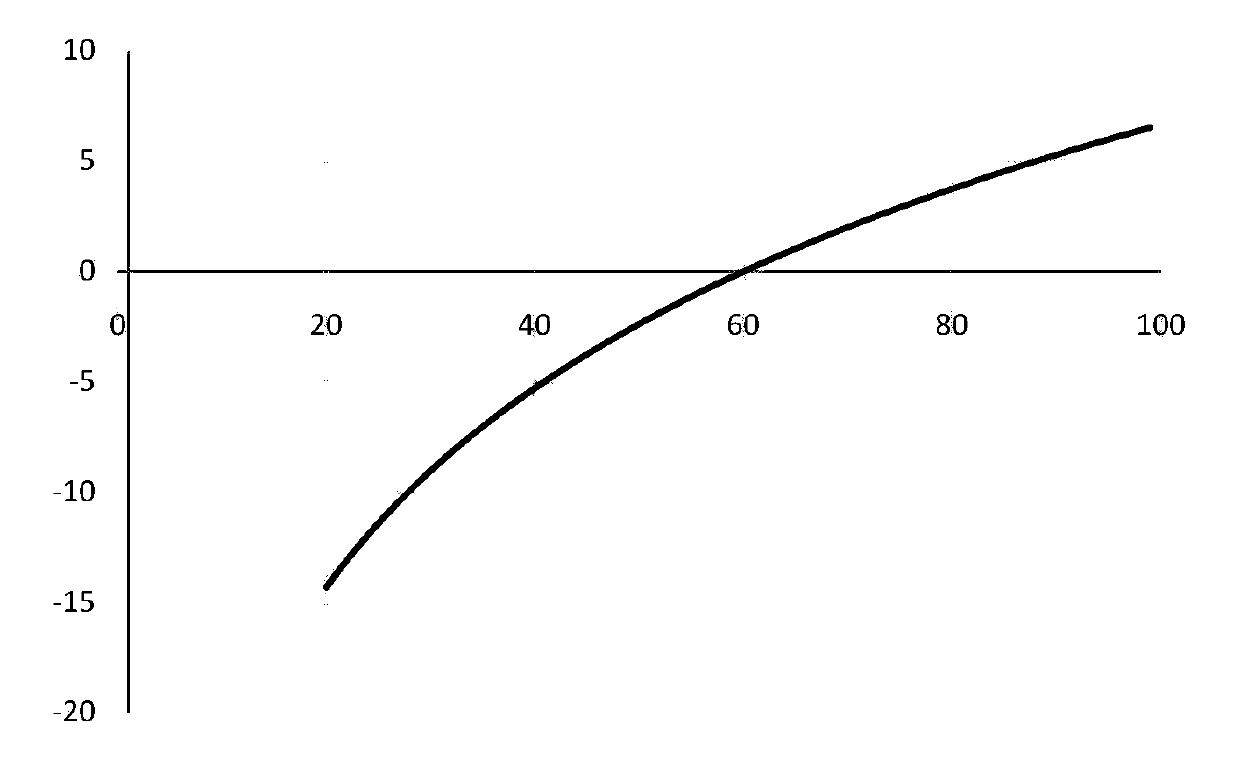
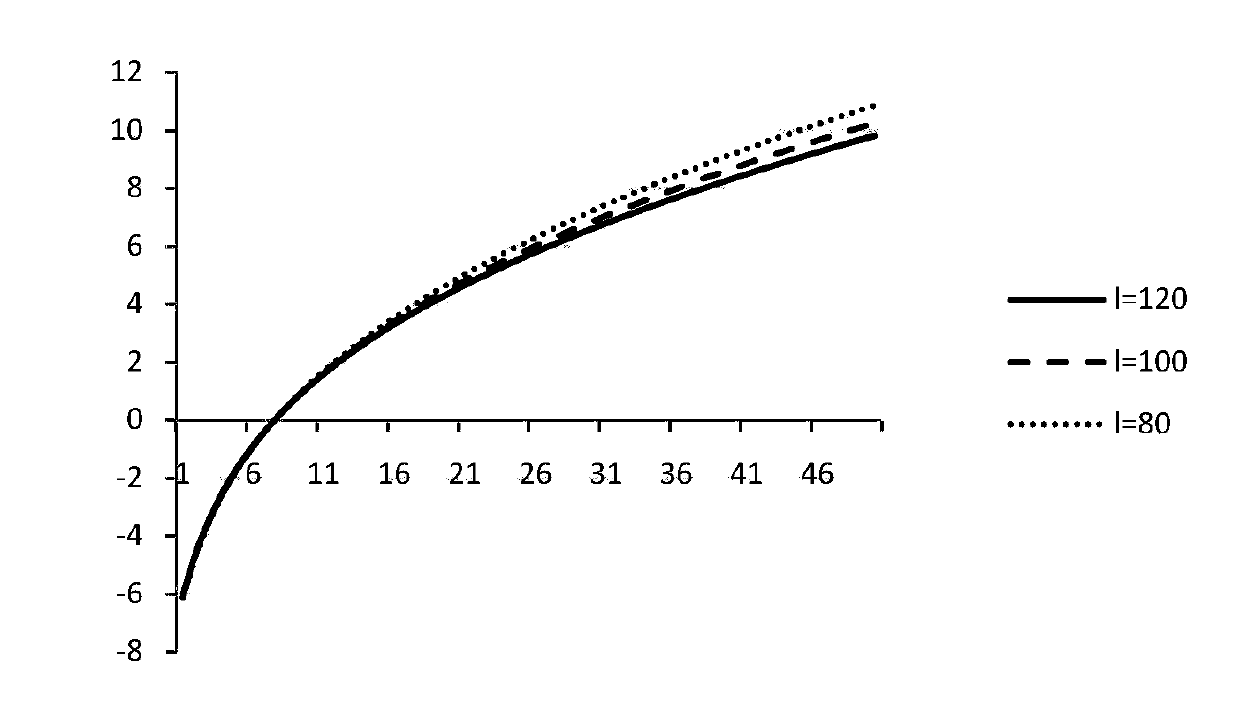
The invention provides an urban rail transit elevated line planning method and device based on a sound environment, and relates to the technical field of urban rail transit. The method comprises the steps that key parameters are acquired, wherein the key parameters are characteristic parameters obtained after urban rail transit elevated line characteristic simplification, and the key parameters are composed of the train speed, the gallery width, the barrier type and the running density; according to the train noise correction amount, the urban rail transit elevated line is planned, key parameters obtained after complex correction parameter simplification are adopted, and planning workers can conveniently achieve rail transit elevated line planning optimization work.
Owner:中国地铁工程咨询有限责任公司
Travel route determination method and device based on shared bicycle
InactiveCN108898241ASolve technical issues that degrade the travel experienceSimplify the planning processReservationsForecastingSingle vehicleComputer science
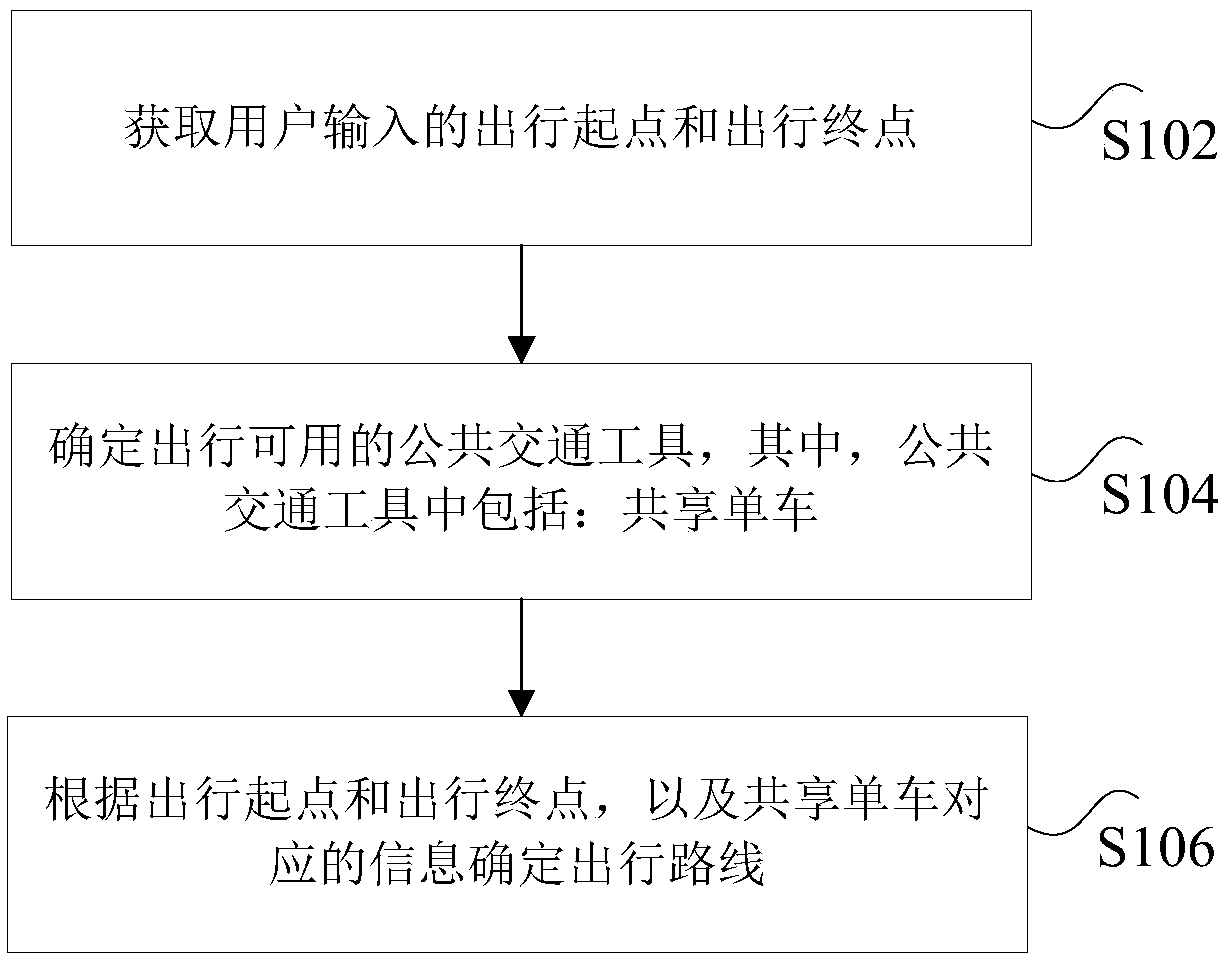
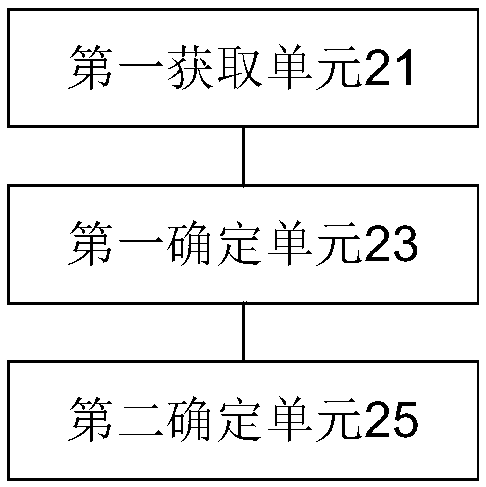
The invention discloses a travel route determination method and device based on a shared bicycle. The method comprises the following steps: obtaining the travel start point and the travel end point inputted by the user; determining the public transport means available for traveling, wherein the public transport means include the shared bicycle; and determining the travel route according to the travel start point and the travel end point and the information corresponding to the shared bicycle. The technical problem in the related technology that route planning is tedious under the condition that the user selects the combined public transport means including the shared bicycle as the travel means and the travel experience of the user decreases can be solved.
Owner:ZHUHAI UNILINK TECH CO LTD
Oil consumption, driving track and safe driving integrated remote monitoring system
PendingCN111741042AEliminate abnormal lossSimplify planning and accounting statisticsProgramme controlComputer controlRemote monitoring and controlSafe driving
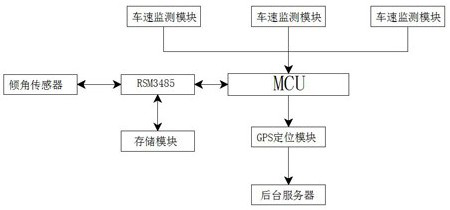
The invention discloses an oil consumption, driving track and safe driving integrated remote monitoring system. The system comprises a vehicle speed monitoring module, an oil consumption acquisition module, a driving track monitoring module, an inclination angle sensor, an RSM3485, a storage module, an MCU module, a GPS positioning module and a background server. The system takes measurement of the actual fuel consumption of an engine as a fuel consumption basis, so that the behavior of stealing fuel from a fuel tank or the behavior of falsely opening a refueling bill has no significance, andthe actual fuel consumption condition can be conveniently read through a fuel consumption display screen or a background monitoring terminal.
Owner:四川省派瑞克斯光电科技有限公司
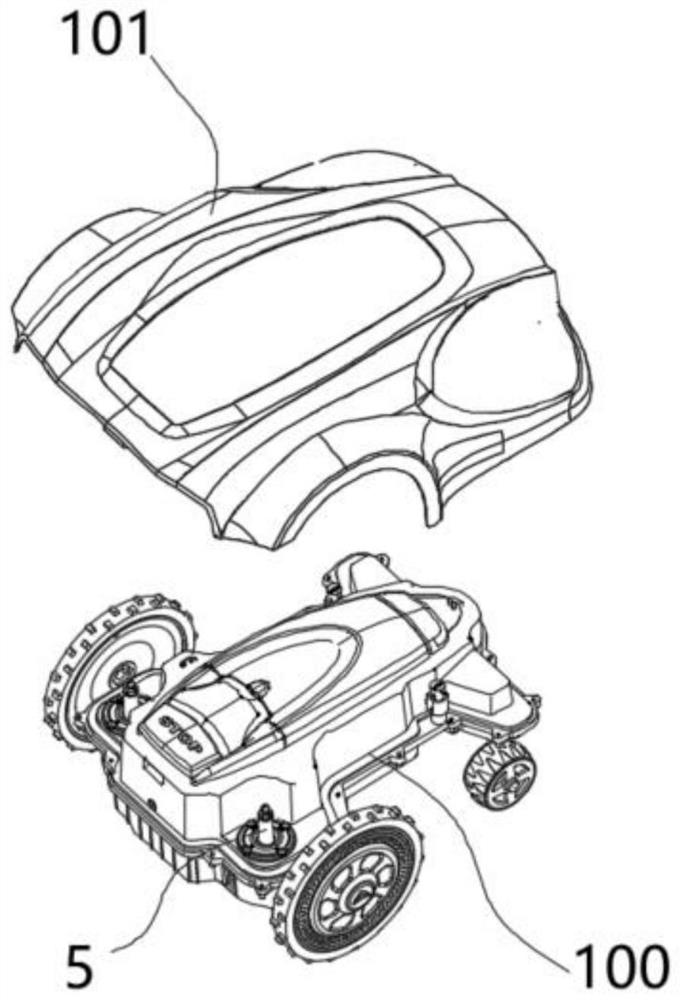
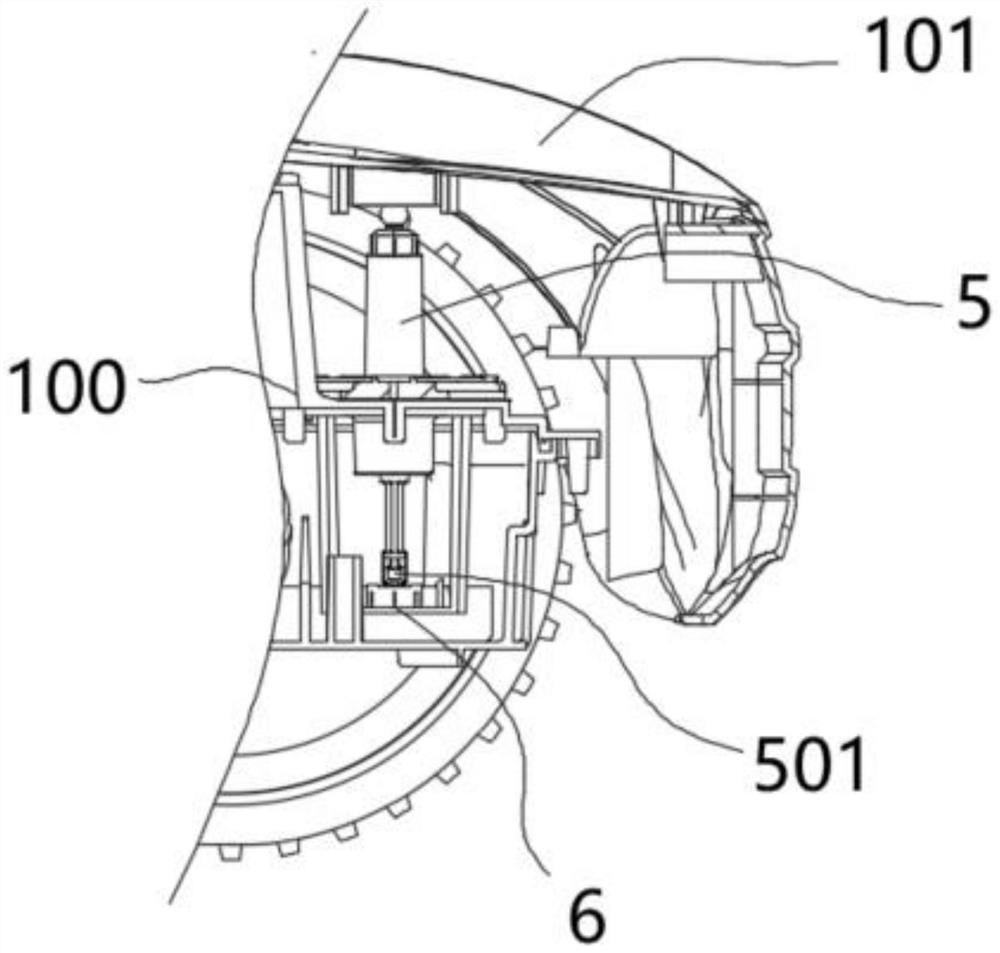
Obstacle avoidance method and automatic walking equipment
PendingCN114355934AReduce grass areaSimplify the planning processPosition/course control in two dimensionsSimulationObstacle avoidance
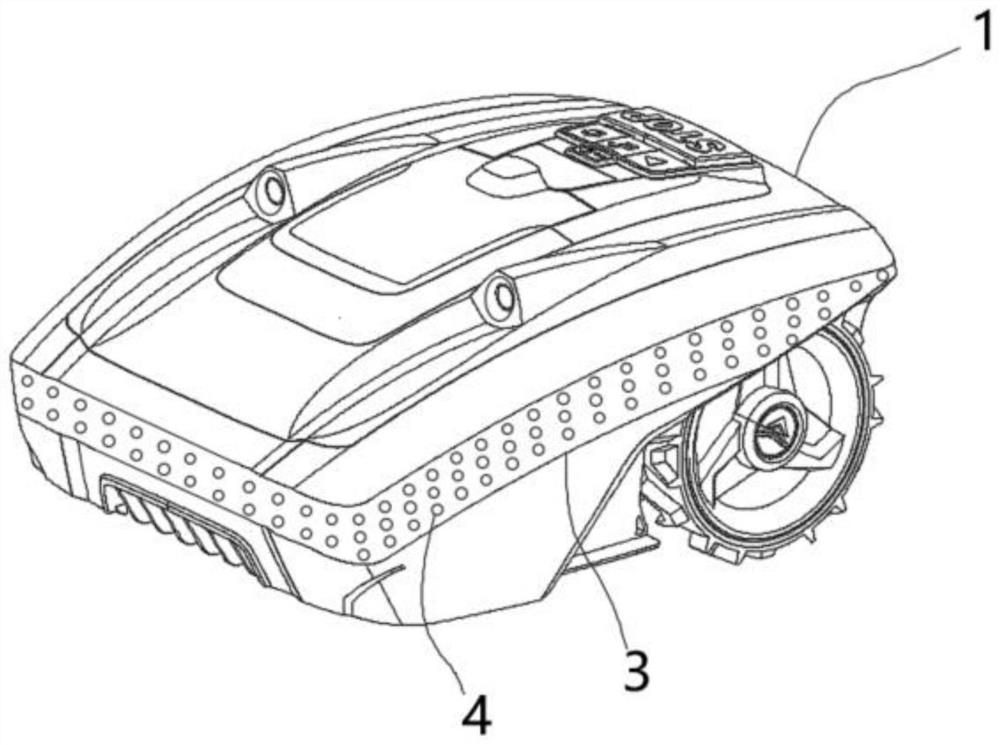
The invention provides an obstacle avoidance method and automatic walking equipment. According to the automatic walking device, after collision is detected, the broken-line-shaped obstacle avoidance path is executed, the obstacle avoidance width can be provided through the deflection distance between the bending angle position of the obstacle avoidance path and the original specified path, the automatic walking device returns to the original walking path direction after obstacle avoidance, and traversal operation continues to be executed along the original specified path. According to the obstacle avoidance mode, the obstacle can be bypassed at a short distance, and operation is carried out by being close to the edge of the obstacle as far as possible, so that the defects that the grassland near the obstacle is not cut or the cutting effect is poor and is not flat enough in an existing obstacle avoidance mode are overcome.
Owner:NANJING SUMEC INTELLIGENT TECH CO LTD
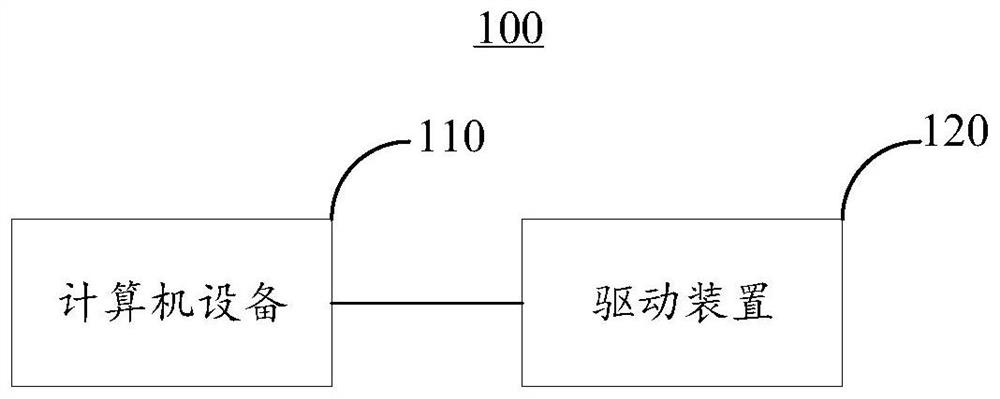
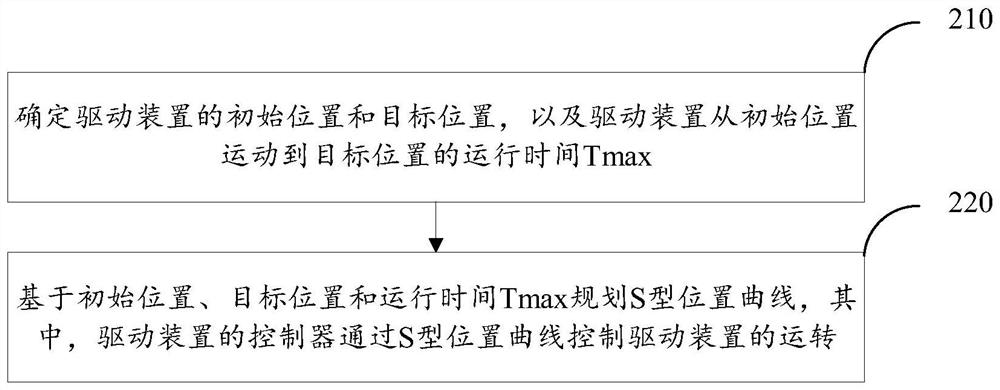
Control method and device of driving device and control method of unmanned equipment
PendingCN114326842APromise to stopAvoid shakingSpeed/accelaration control using electric meansSimulationControl theory
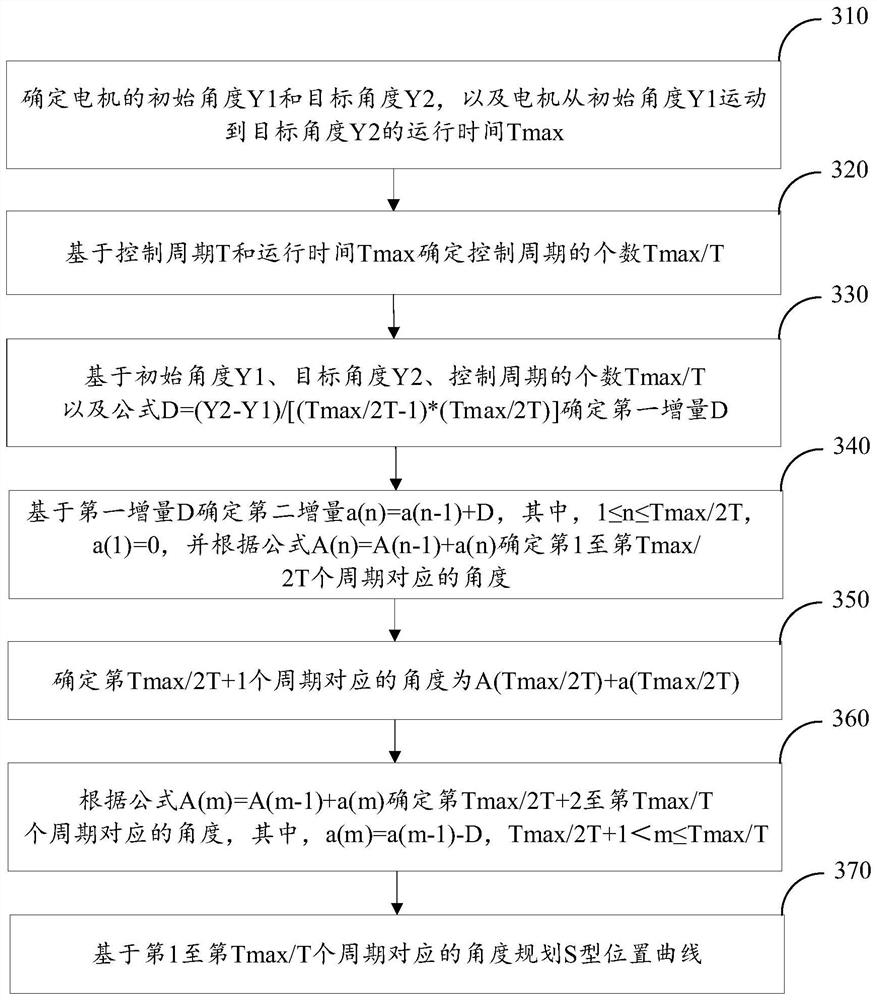
The invention provides a control method and device of a driving device and a control method of unmanned equipment. The control method of the driving device comprises the steps that the initial position and the target position of the driving device and the running time Tmax of the driving device moving from the initial position to the target position are determined; an S-shaped position curve is planned based on the initial position, the target position and the running time Tmax, and a controller of the driving device controls running of the driving device through the S-shaped position curve. According to the technical scheme, the path planning process can be simplified, and the complexity of a planning algorithm is reduced.
Owner:GUANGZHOU XAIRCRAFT TECH CO LTD
Path planning method and device, unmanned equipment and storage medium
ActiveCN112797983ASimplify the planning processImprove efficiencyNavigational calculation instrumentsControl engineeringIndustrial engineering
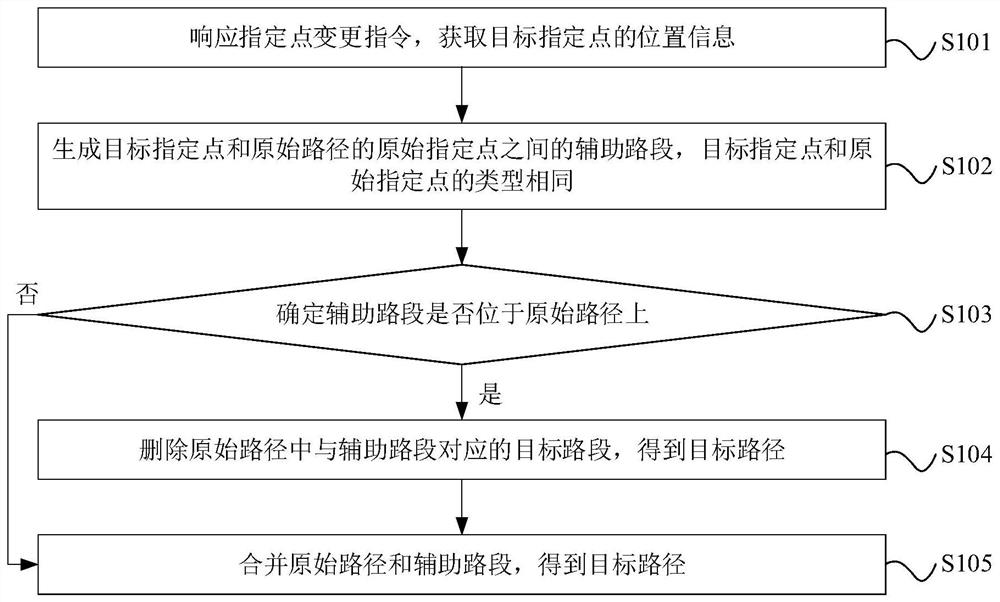
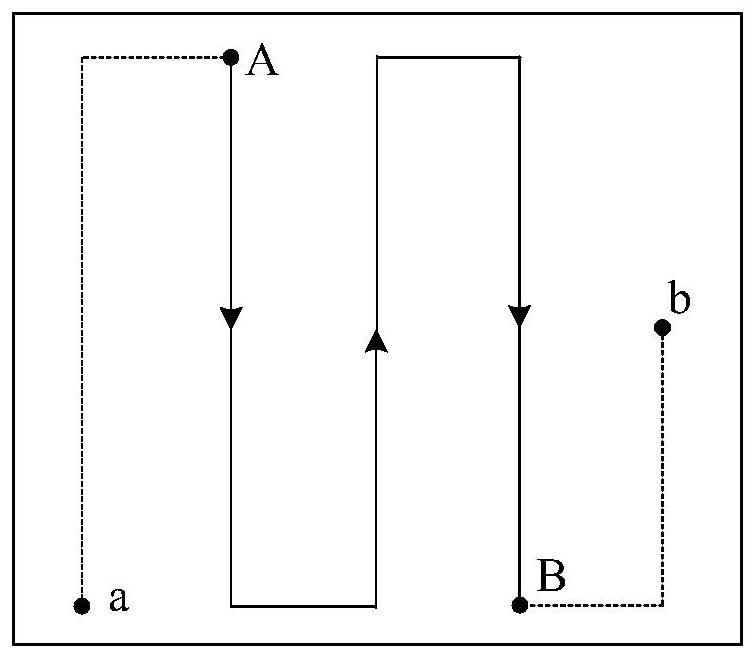
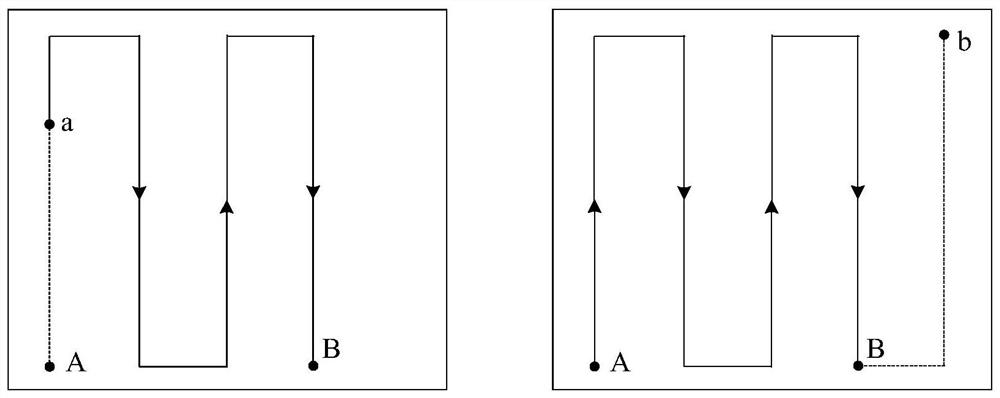
The embodiment of the invention relates to the field of path planning, and provides a path planning method and device, unmanned equipment and a storage medium, when an original specified point needs to be changed, an original path is not re-planned, the position information of a target specified point is firstly obtained, and an auxiliary road section between the target specified point and the original specified point is generated; the target specified point and the original specified point have the same type; then, whether the auxiliary road section is located on the original path or not is determined, if the auxiliary road section is located on the original path, the part corresponding to the auxiliary road section is deleted from the original path, and the remaining part is the target path; and if the auxiliary road section is not located on the original path, the auxiliary road section is added on the basis of the original path to obtain a target path. Therefore, the path planning process is simplified, and the path planning efficiency and the operation efficiency of unmanned equipment are improved.
Owner:GUANGZHOU XAIRCRAFT TECH CO LTD
A dynamic intelligent control system for bulk grain vehicle unloading and warehouse entry and exit operations
ActiveCN108154334BEnsure safetyReal-time warehouse dataCo-operative working arrangementsAutomatic controlRadar
The invention discloses a dynamic intelligent control system for truck dumper discharging and warehousing operations. The system comprises an acquisition layer, a recognition layer, a transmission layer, a data layer, a business layer and a user layer from bottom to top. The dynamic intelligent control system comprehensively uses an RFID (radio frequency identification) technology, a radar technology, a video recognition artificial intelligence technology, a comprehensive wiring technology, an automatic control technology and a database technology to provide intelligent management means for dynamically monitoring the port truck dumper discharging and warehousing operations, manual prevention and control of the truck dumper discharging and warehousing operations is transformed into automatic prevention and control by a computer, an unattended wagon balance system is seamlessly connected with an unmanned gate system, an idle wagon balance can be sufficiently used, cargo safety is ensured, the planning process of a production operation system is simplified, the working intensity of system workers is reduced, human errors in the operation process are decreased, and dumping operation efficiency is greatly improved.
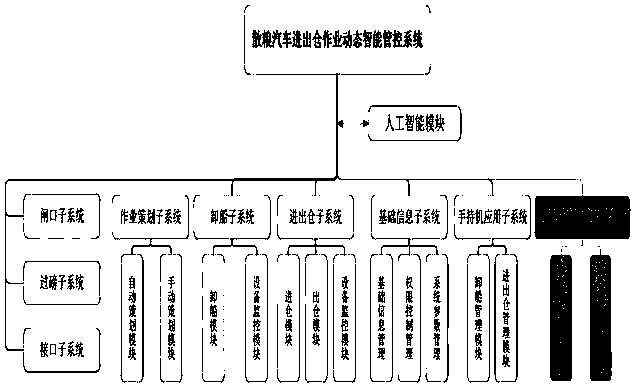
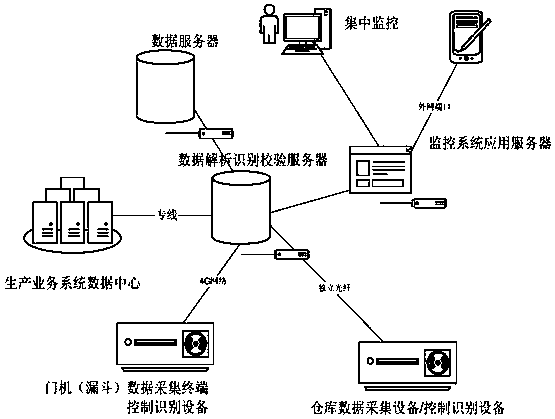
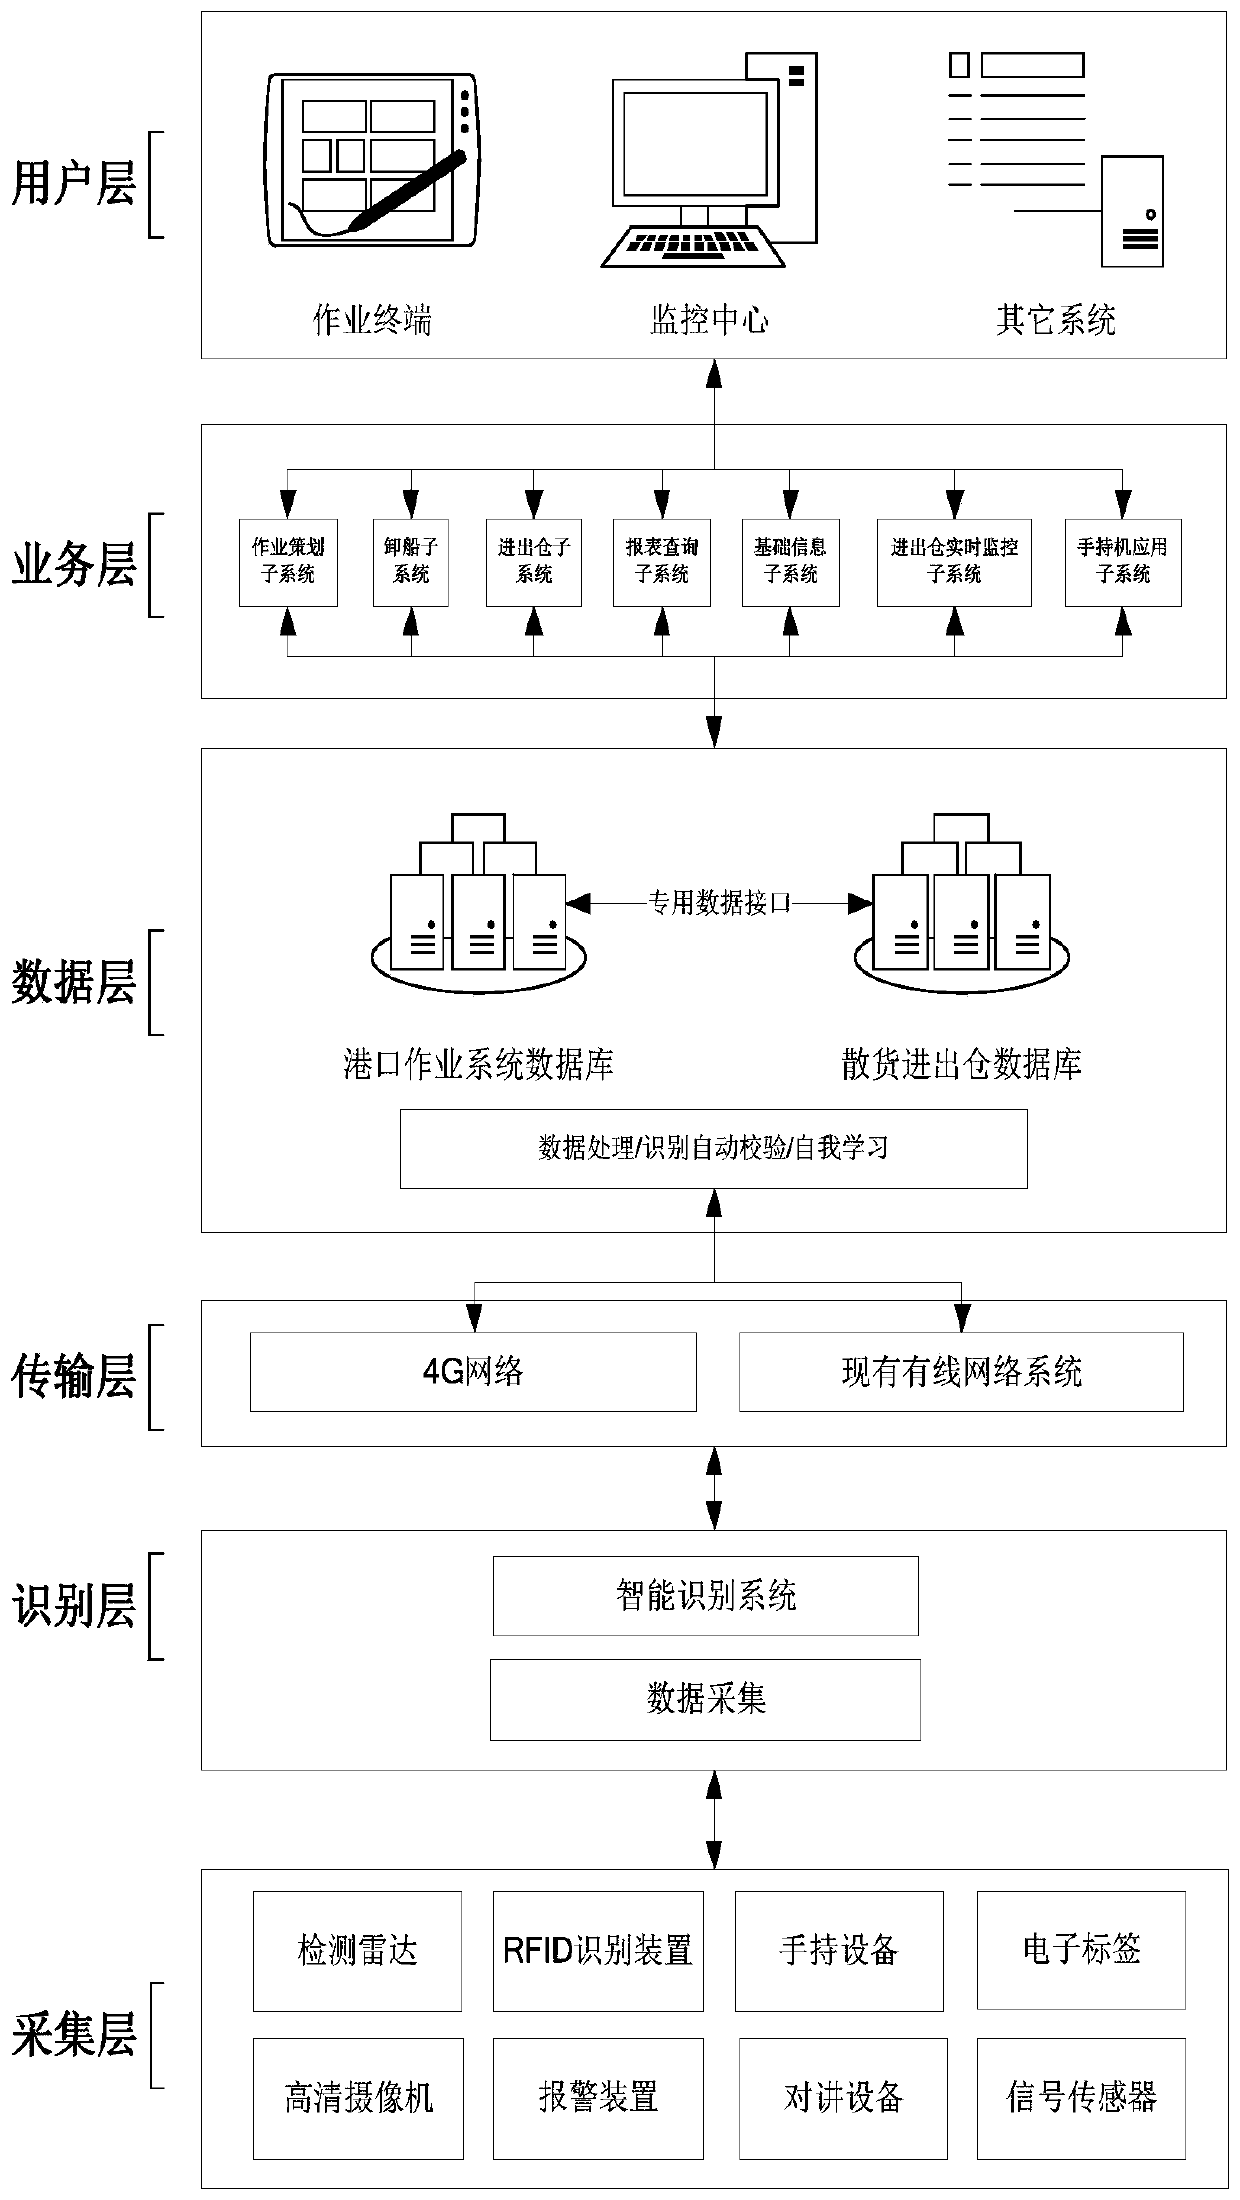
Owner:广州玖峰信息科技有限公司
A method for multi-dimensional collaborative power grid planning
InactiveCN103116865BImprove convenienceHigh feasibilityData processing applicationsSpecial data processing applicationsPower gridCost calculation
The invention discloses a multidimensional collaborative power grid planning method which includes the processes: acquiring geographic environmental information data and calculating comprehensive construction cost data by a rasterized map; building a power grid planning model; and calculating the solution of a power grid planning scheme by an optimal ant colony algorithm according to the acquired data and the power grid planning model. The method includes the steps: comprehensively considering substation locating and sizing, line selection and line corridor selection; and building a multidimensional collaborative power grid planning model considering complicated environmental influence. The multidimensional collaborative power grid planning method can accurately consider the influence of environmental factors on power grid planning. Line construction cost calculation precision is improved, and estimation difficulty is reduced. Catalytic elements are generated according to deviation of the local movement direction and the target movement direction of ants, so that the state transition rule of the ants is improved. The construction cost of lines on a mass raster and a substation is full-automatically and rapidly calculated, and calculation precision and efficiency are remarkably improved.
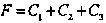


Owner:NORTH CHINA ELECTRIC POWER UNIV (BAODING)
Technique of encoding harq feedback information with two separate codewords with unequal error protection for dtx and ack/nack
InactiveCN102754384AAvoid damageReduce riskError prevention/detection by using return channelTransmission path divisionTelecommunicationsCarrier signal
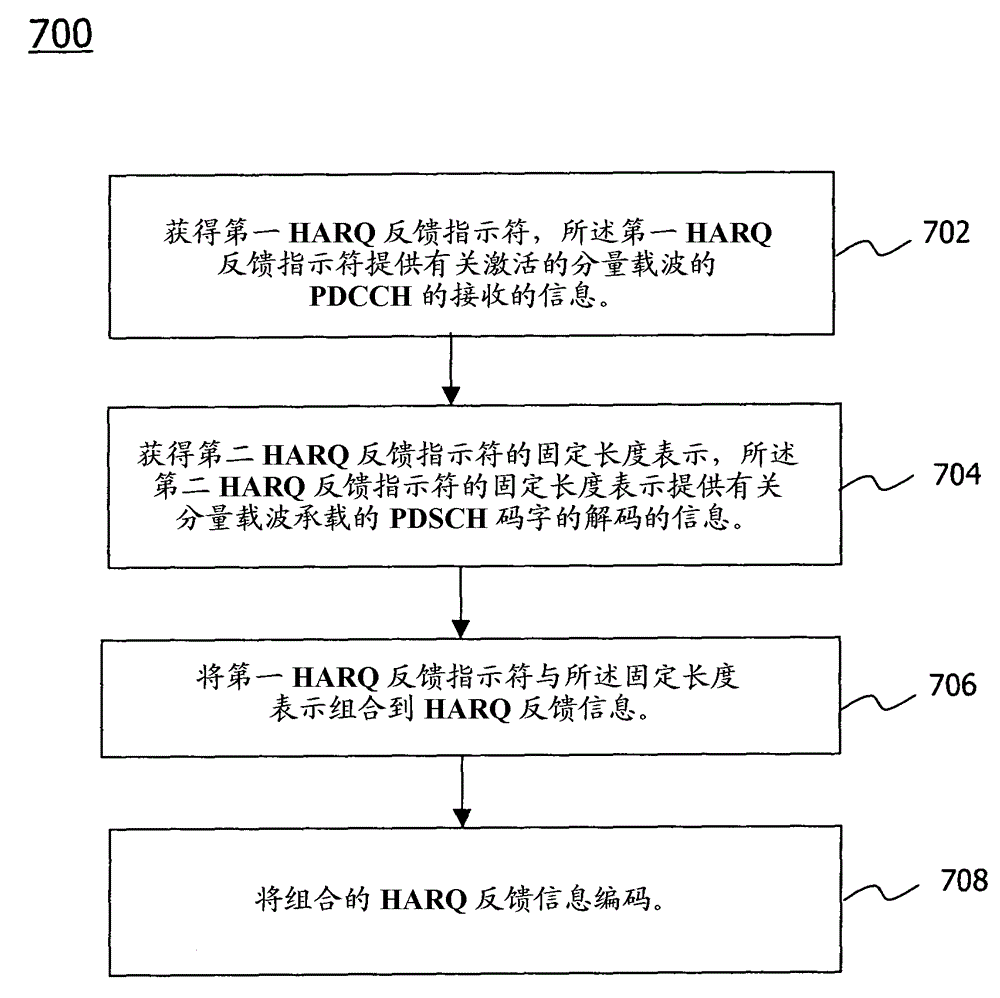
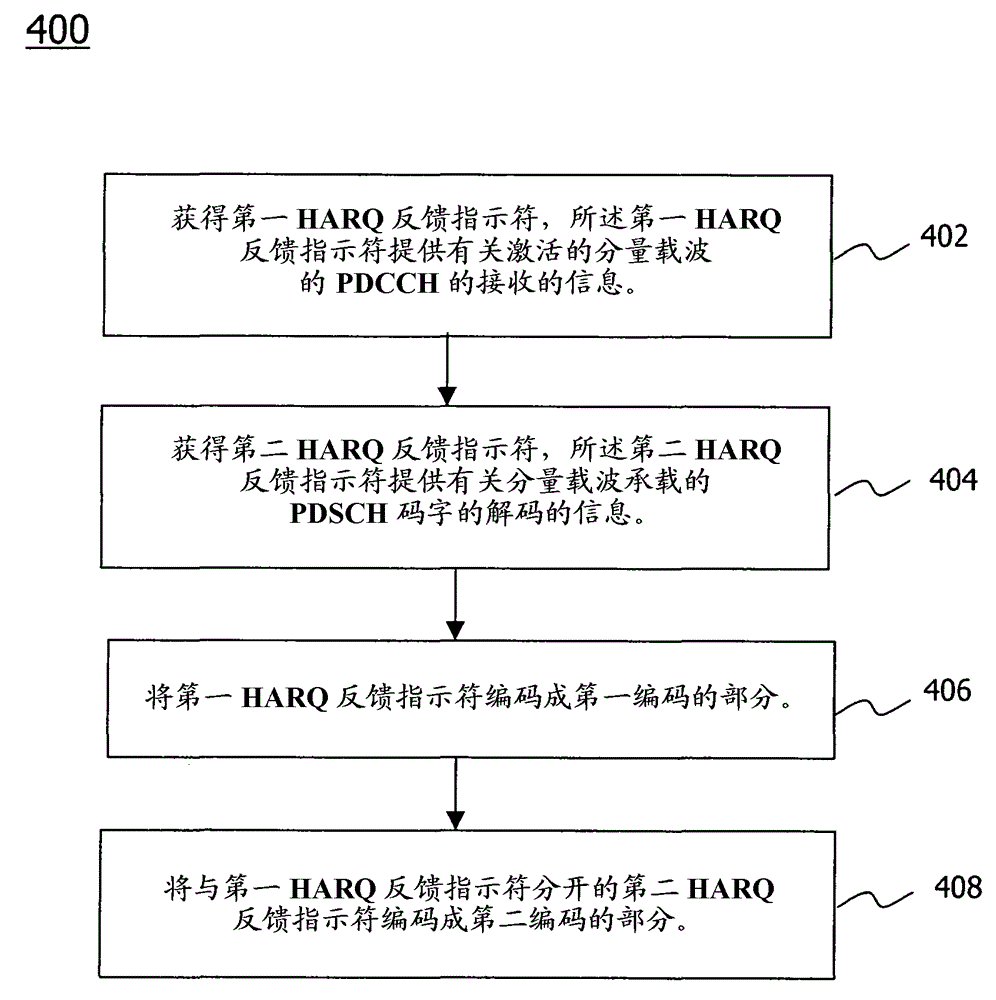
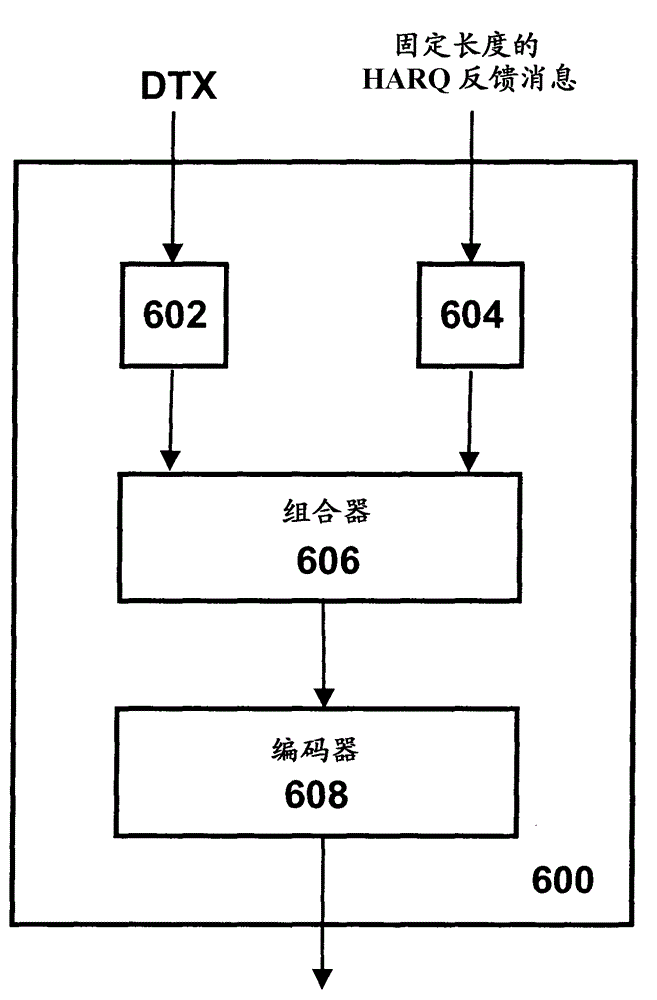
A technique for encoding downlink Hybrid Automatic Repeat Request, HARQ, feedback information in a mobile station supporting aggregated component carriers is provided. A method implementation of this technique comprises the steps of obtaining (302) first HARQ feedback indicators providing information regarding receipt of Physical Downlink Control Channels, PDCCH, for activated component carriers, obtaining (304) second HARQ feedback indicators providing information regarding decoding of Physical Downlink Shared Channels, PDSCH, codewords carried by the component carriers, encoding (306) the first HARQ feedback indicators into a first coded part, and encoding (308) the first HARQ feedback indicators into a second coded part, wherein the first and the second HARQ feedback indicators are encoded separate from each other.
Owner:TELEFON AB LM ERICSSON (PUBL)
Method and device for establishing BGP peer
ActiveCN111740901ASimplify the planning processSimplify the deployment processData switching networksEngineeringDistributed computing
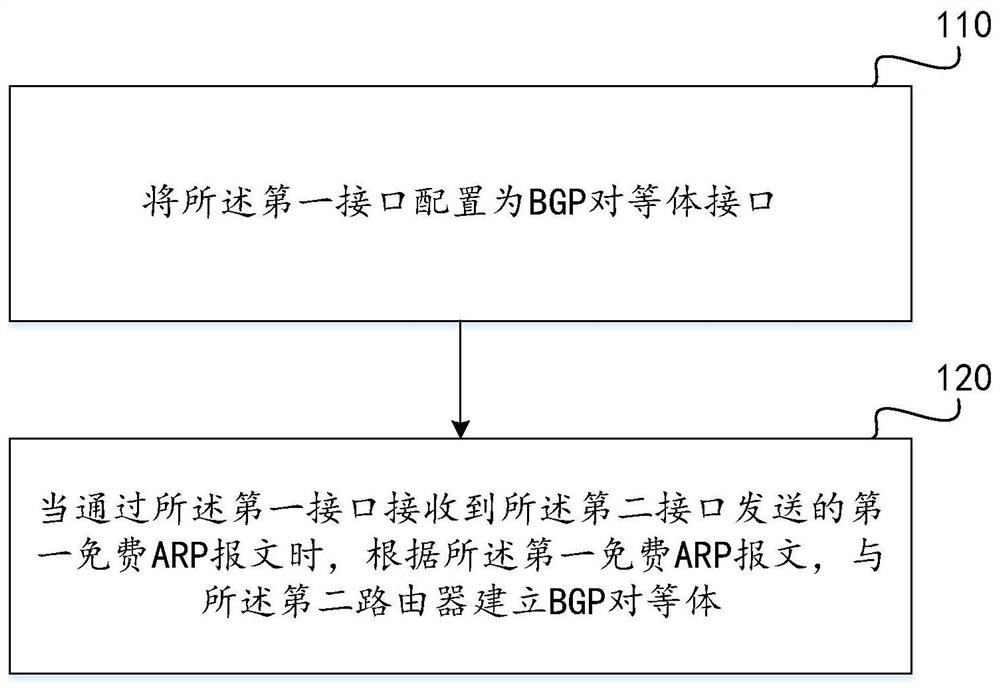
The invention provides a method and device for establishing a BGP peer, the method is applied to a first router, a first interface included in the first router is directly connected with a second interface included in a second router, and the method comprises the following steps: configuring the first interface as a BGP peer interface; and when a first free ARP message sent by the second interfaceis received through the first interface, establishing the BGP peer with the second router according to the first free ARP message.
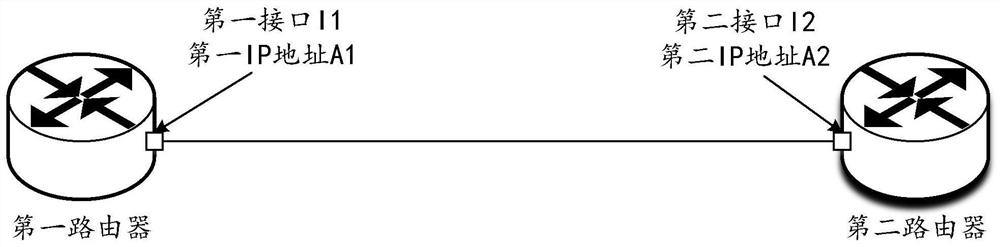
Owner:北京华三通信技术有限公司
A Calculation Method of Spaceborne SAR Real-time Imaging Parameters Suitable for Ship Guidance Imaging
ActiveCN111413695BSimplify the imaging task planning processSimplify the planning processMarine craft traffic controlSatellite radio beaconingScan angleImage mode
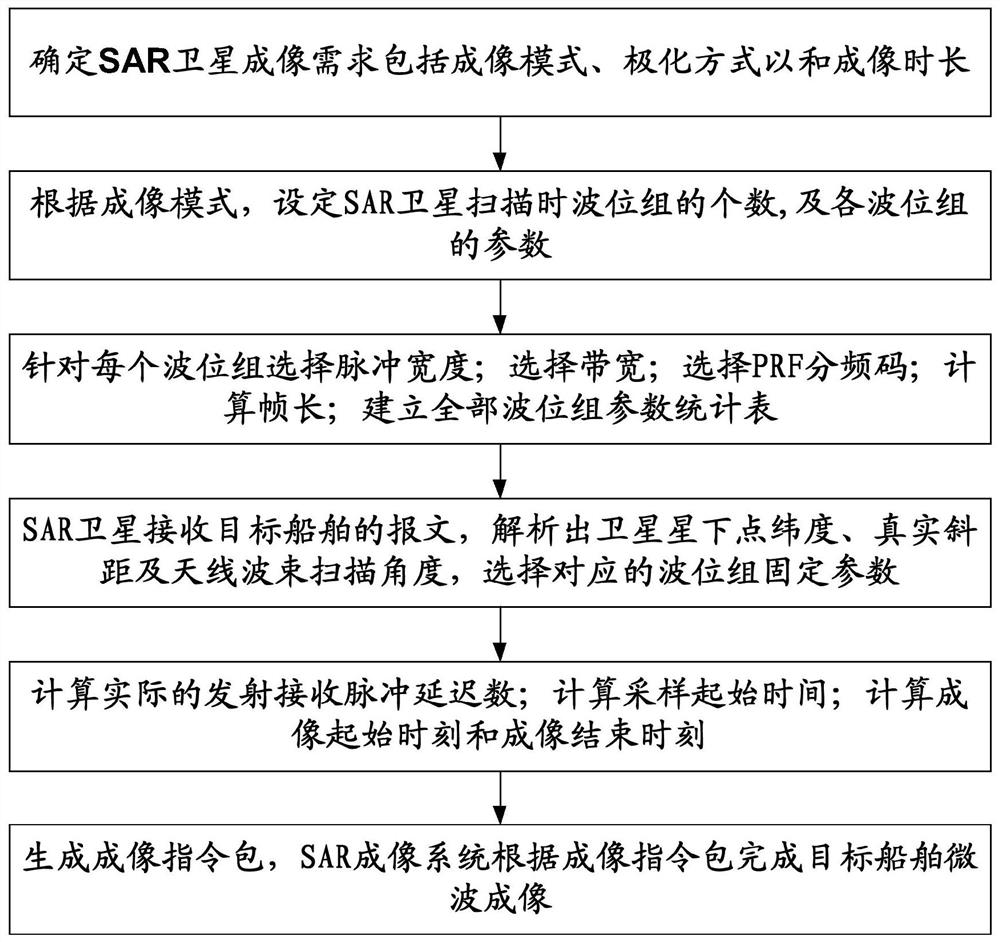
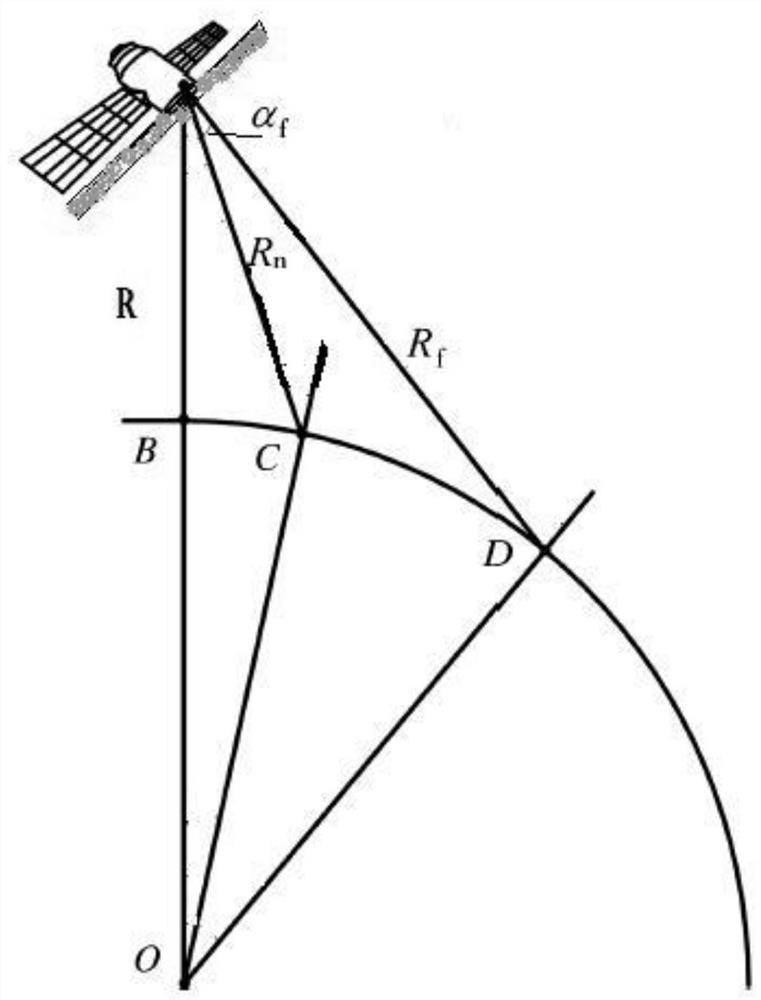
The invention relates to a method for calculating space-borne SAR real-time imaging parameters suitable for ship-guided imaging, belonging to the technical field of autonomous imaging of low-orbit SAR payload satellites; Step 1, determining the imaging mode, polarization mode and imaging duration of the SAR satellite; Step 2 , setting the number of wave position groups, and the parameters of each wave position group; step 3, selecting the pulse width, bandwidth and PRF frequency division code of each wave position group; calculating the frame length; step 4, analyzing the target ship message to obtain The latitude of the sub-satellite point, the real slant distance and the scanning angle of the antenna beam, select the corresponding fixed parameters of the wave position group; Step 5, calculate the actual number of transmit and receive pulse delays, sampling start time, imaging start time and imaging end time; Step 6: The SAR imaging system completes the microwave imaging of the target ship according to the imaging instruction package; the present invention realizes the real-time SAR imaging within a short period of time (shortened to seconds) when the AIS finds the target ship, and greatly improves the timeliness of marine ship monitoring sex and visibility.
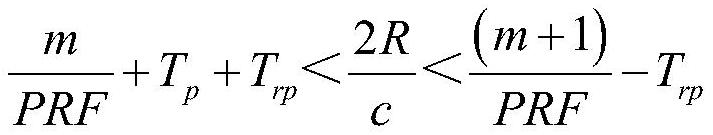
Owner:BEIJING INST OF SPACECRAFT SYST ENG
Acoustic environment-based urban rail transit overhead line planning method and device
ActiveCN110458475BSimplify the planning processImprove work efficiencySubsonic/sonic/ultrasonic wave measurementResourcesNoiseNoise correction
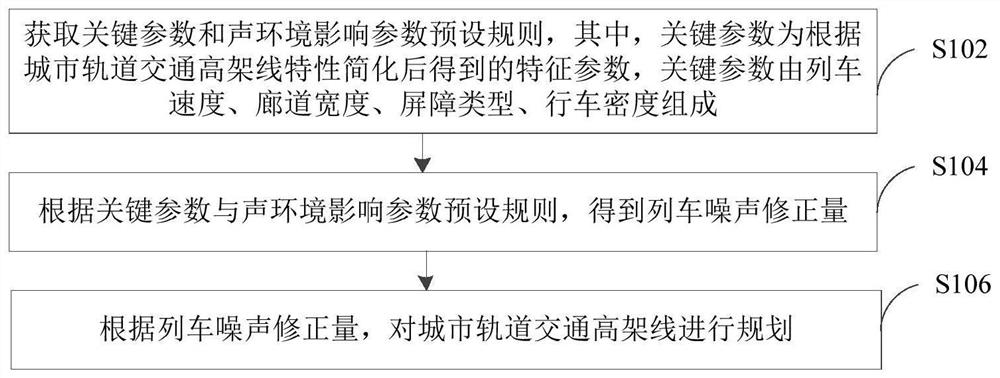
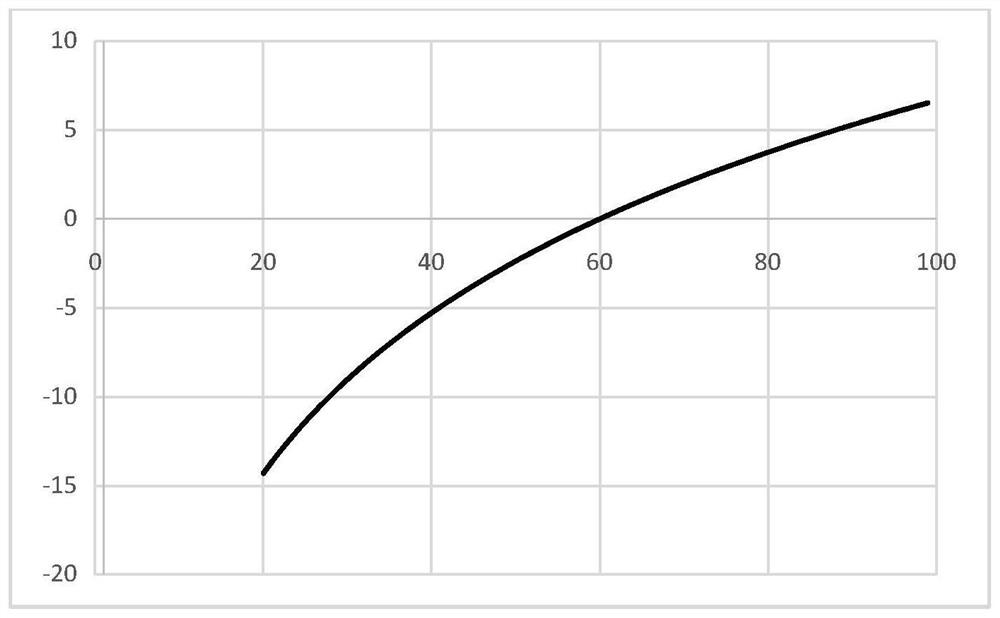
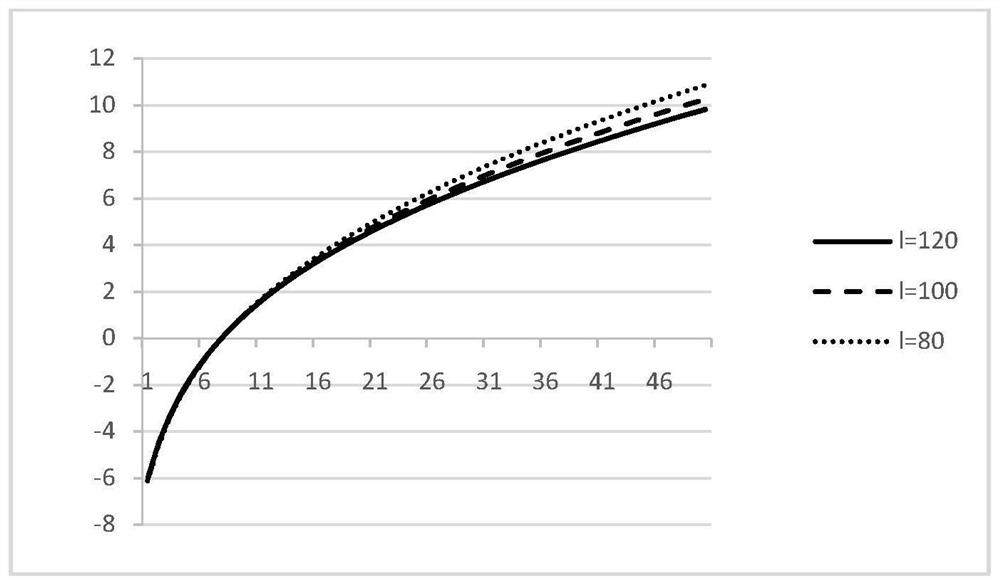
The invention provides an urban rail transit elevated line planning method and device based on a sound environment, and relates to the technical field of urban rail transit. The method comprises the steps that key parameters are acquired, wherein the key parameters are characteristic parameters obtained after urban rail transit elevated line characteristic simplification, and the key parameters are composed of the train speed, the gallery width, the barrier type and the running density; according to the train noise correction amount, the urban rail transit elevated line is planned, key parameters obtained after complex correction parameter simplification are adopted, and planning workers can conveniently achieve rail transit elevated line planning optimization work.
Owner:中国地铁工程咨询有限责任公司
Oil-lubricated kinematic module connecting system, mainly the transmission or bearing modules of industrial robot; method of kinematic module lubrication
PendingUS20200298428A1Increases in lifetimeImprove reliabilityGear lubrication/coolingManipulatorLubricationOil content
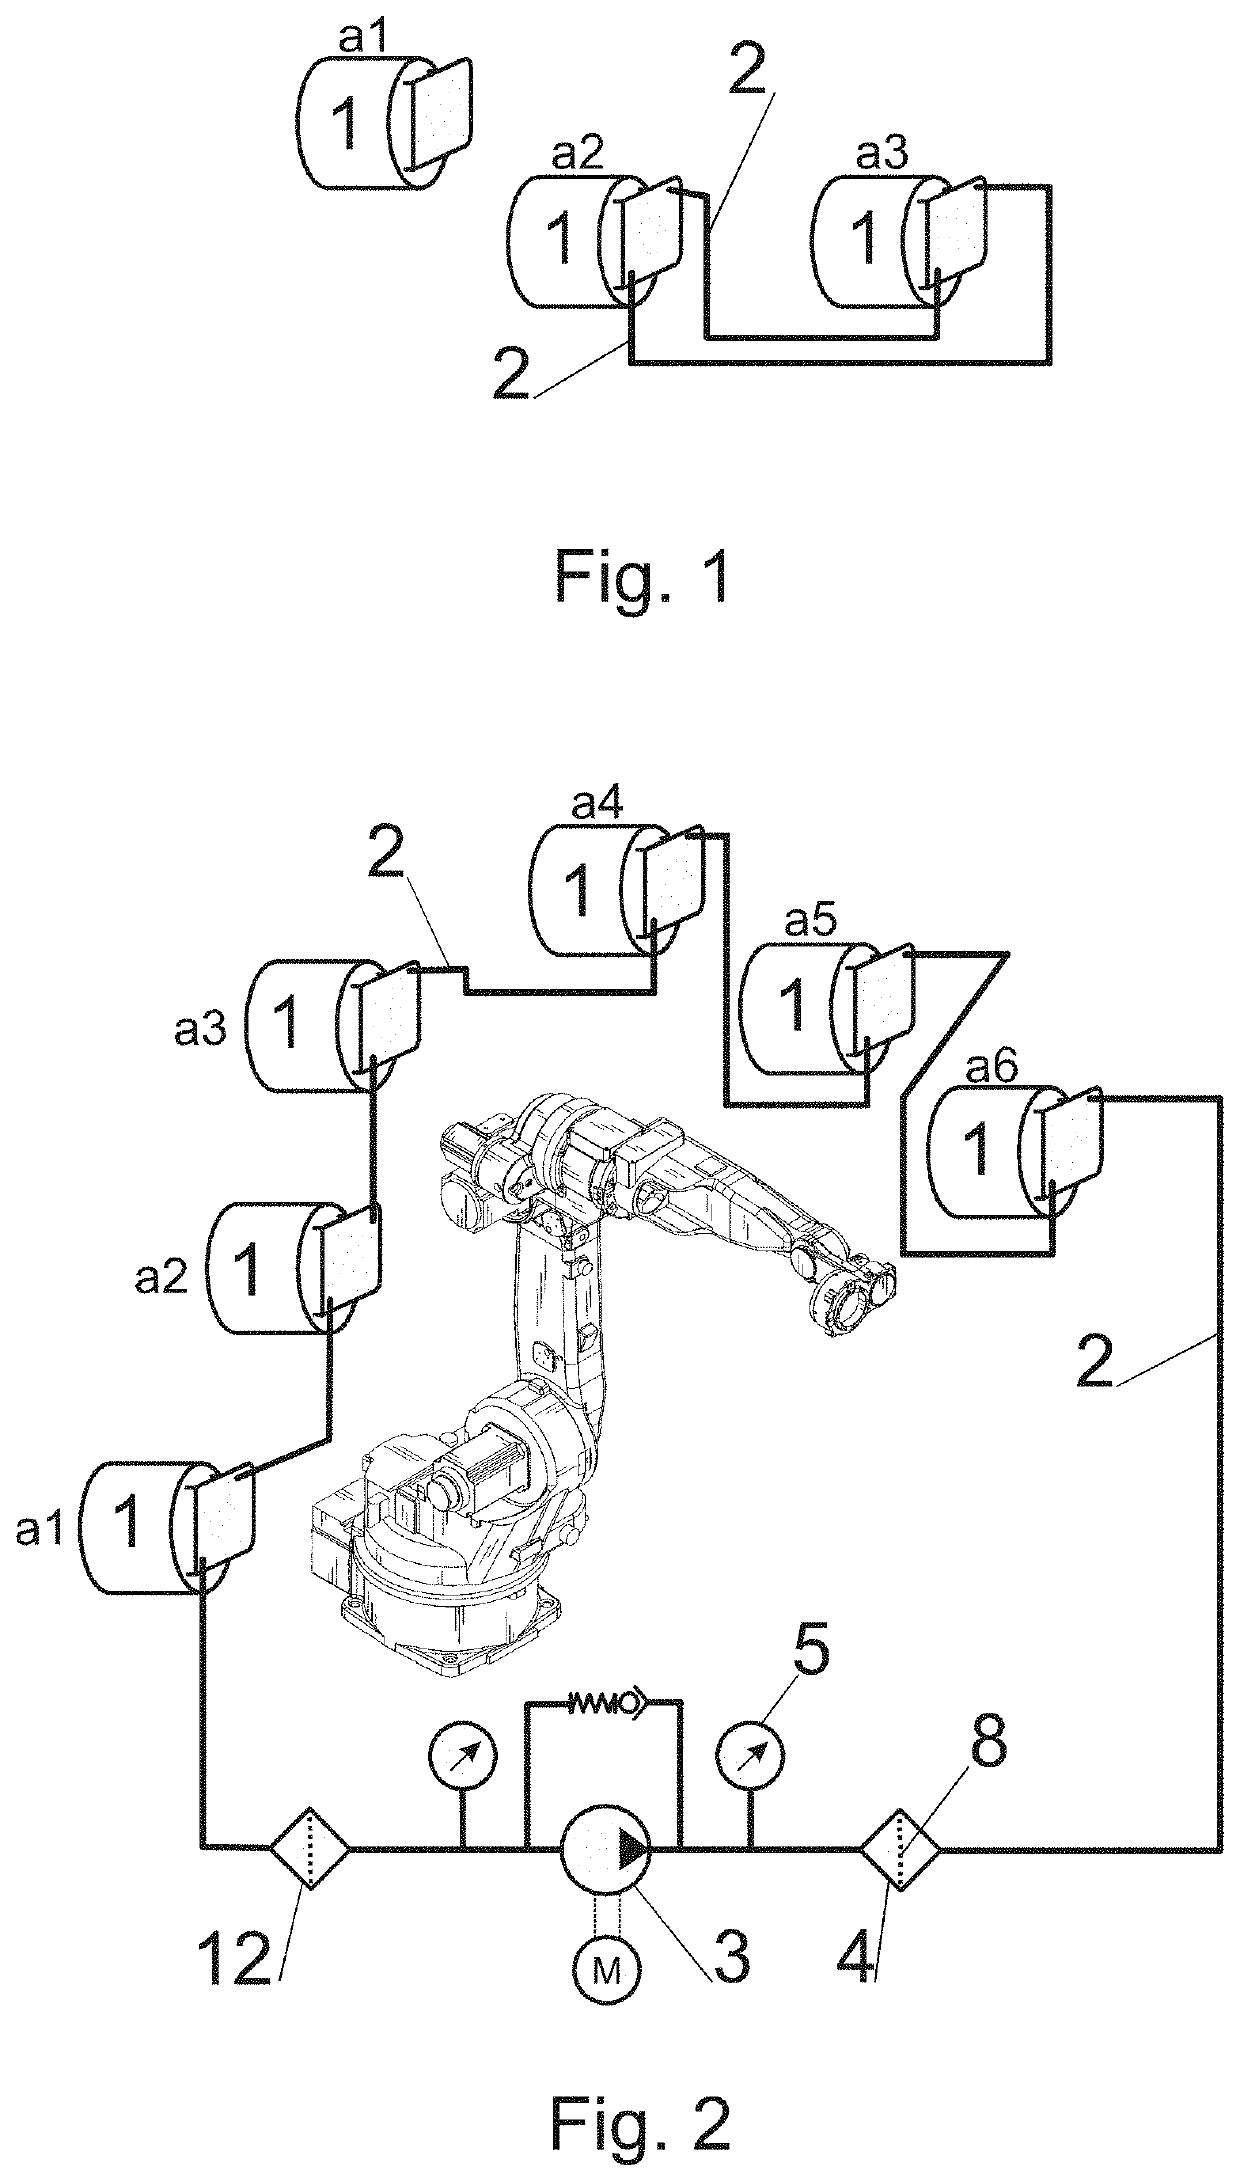
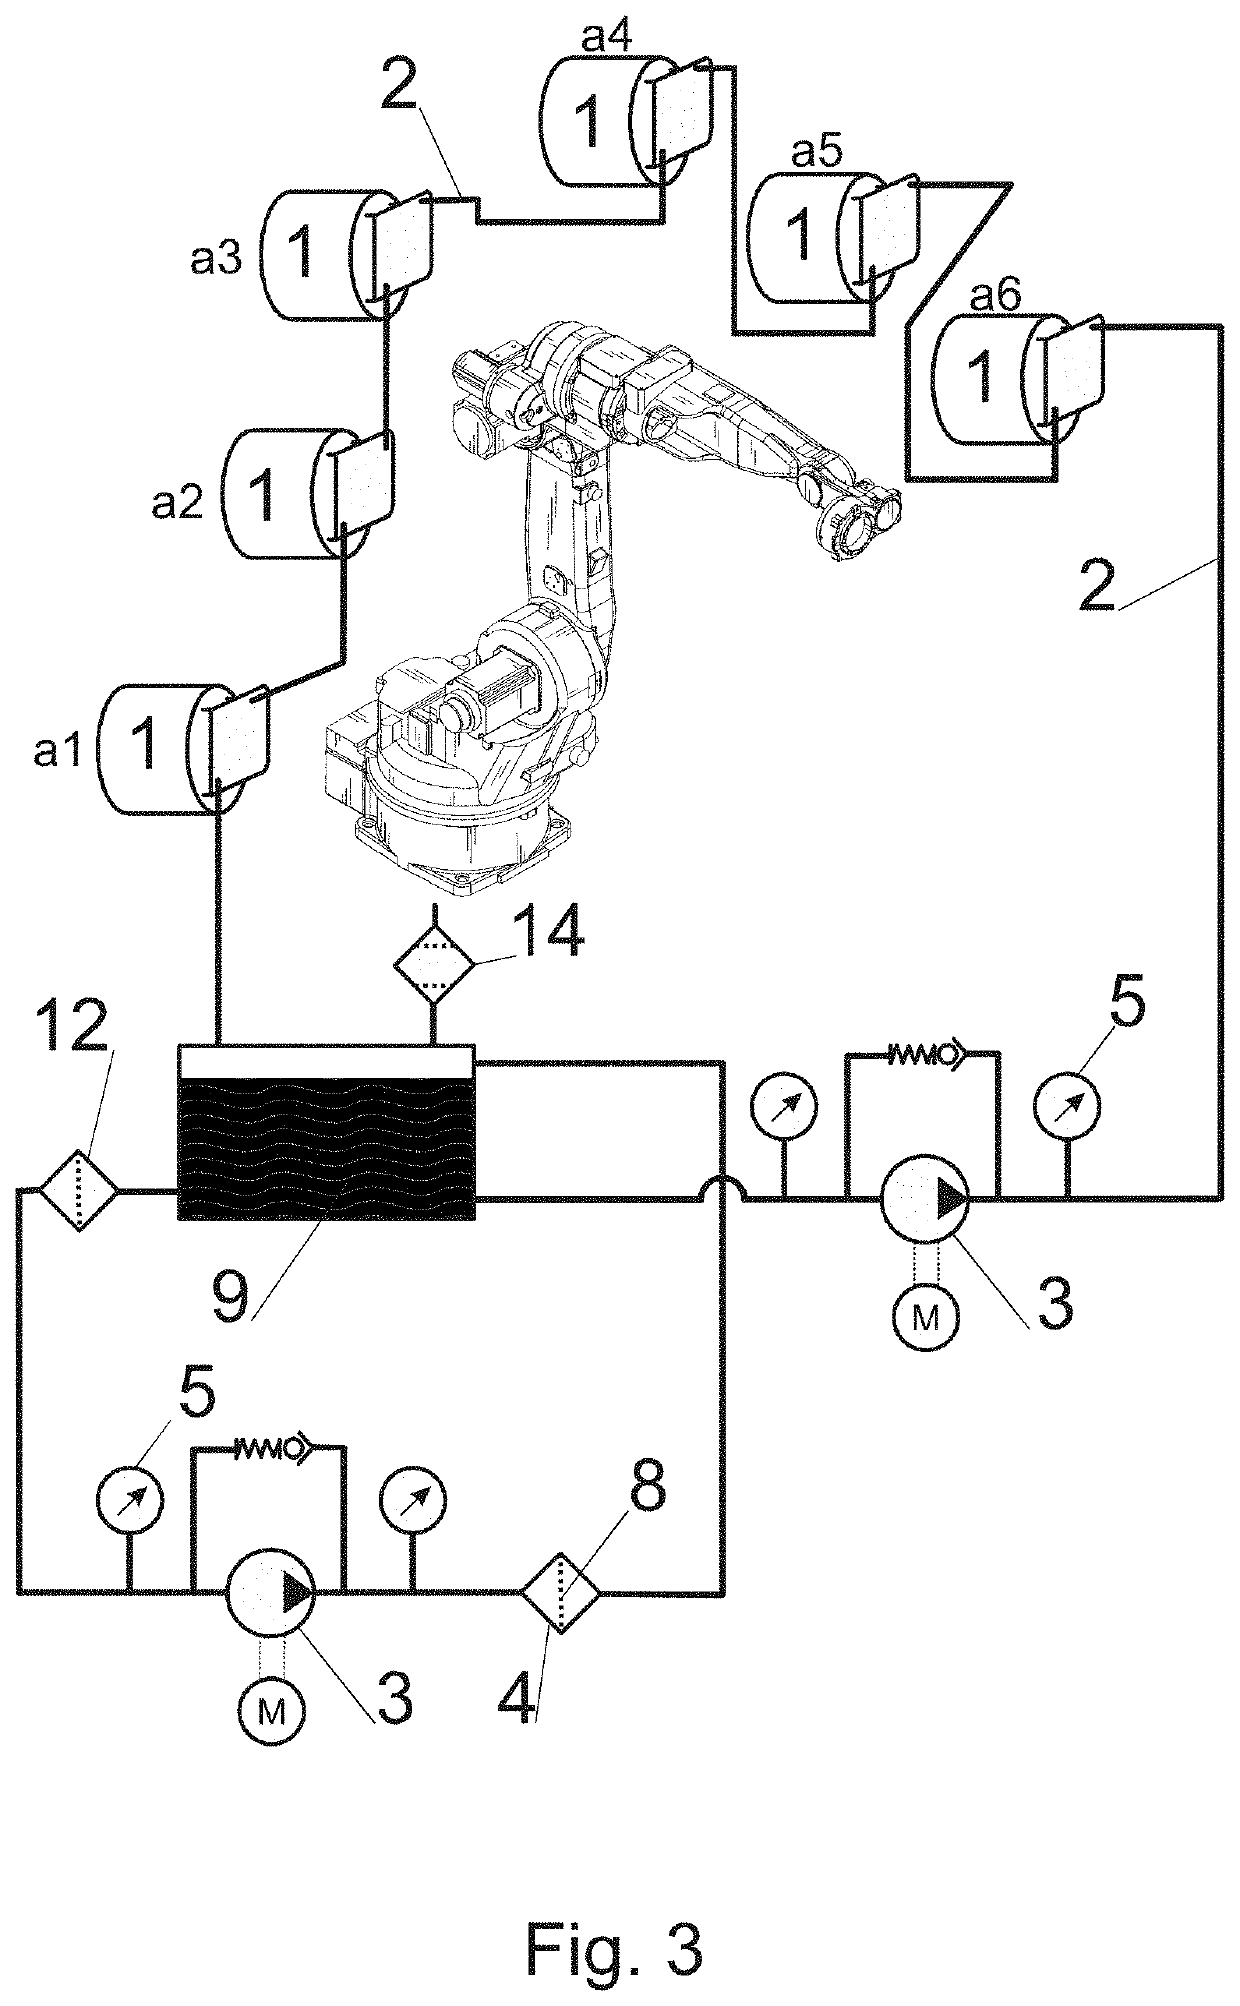
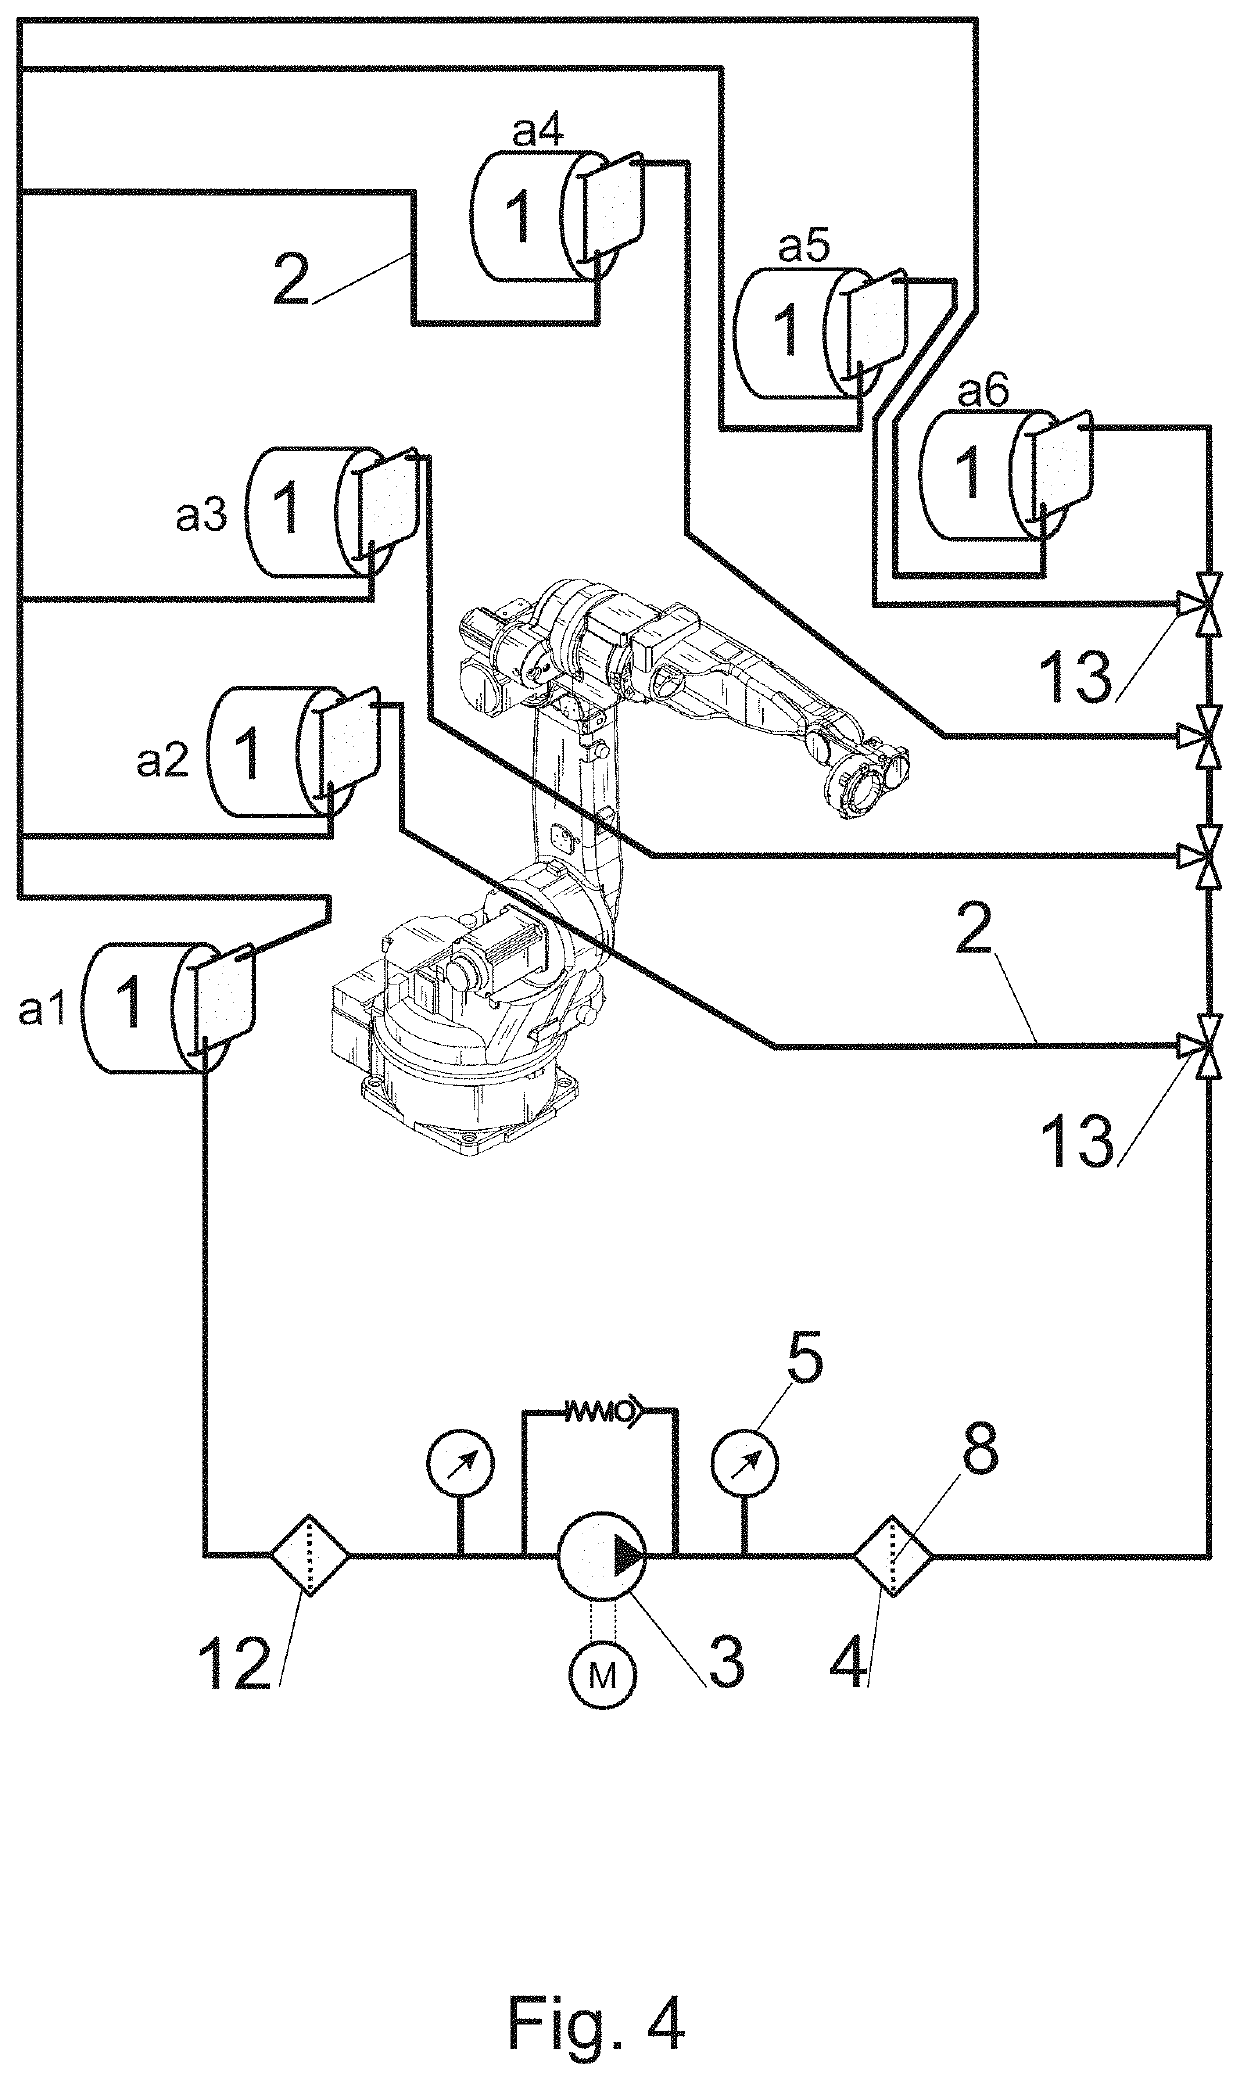
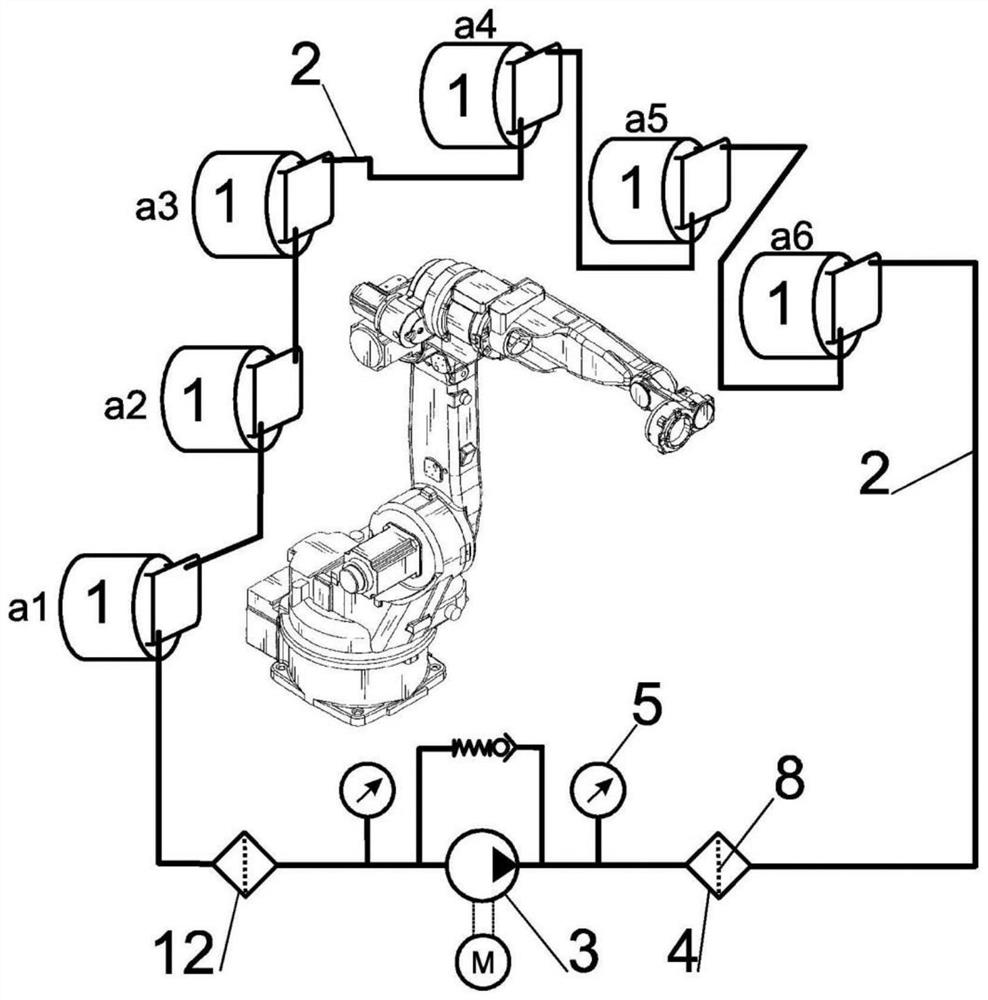
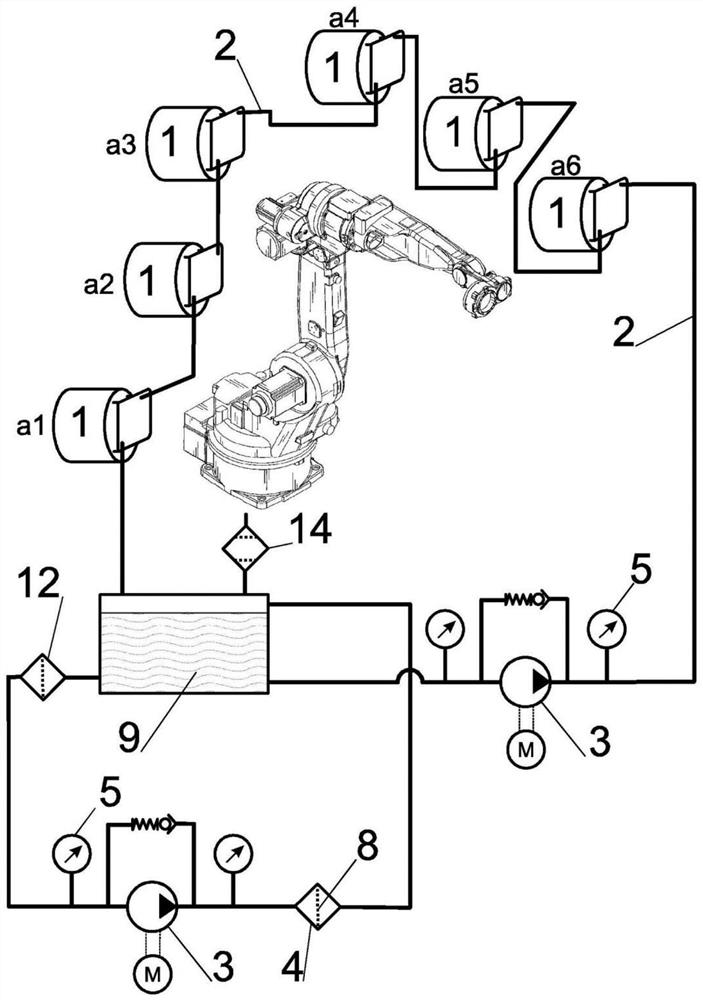
The oil content of at least two kinematic modules (1) in different axes of the industrial robot is connected by the oil line (2) to the closed circuit of the oil between interconnected kinematic modules (1). In preferred arrangement, the system includes the pump (3) engaged in pushing the oil in the upper-mounted kinematic module (1) and also the filtration device (4) for filtering the oil in the circulating circuit or in a separate circuit with the oil tank (9). The system may also include at least one diagnostic element (5), for example an oil temperature sensor or an oil pressure sensor or an oil pollution sensor connected to the evaluation unit (6). The evaluation unit (6) can be interconnected with the industrial robot control system, whereby the oil economy is controlled and planned depending on the actual load of the individual kinematic modules (1). By this arrangement, you can achieve the condition in which the oil from the kinematic module (1) circulates in shared circulation with the oil from another kinematic module (1), whereas the oil gets purified through the filter device (4) by using the pump (3).
Owner:EROBOT J SA
A humanoid robot control method, device, computer equipment and storage medium
ActiveCN112783043BIncrease flexibilityImprove stabilityProgramme controlComputer controlSimulationAngular velocity
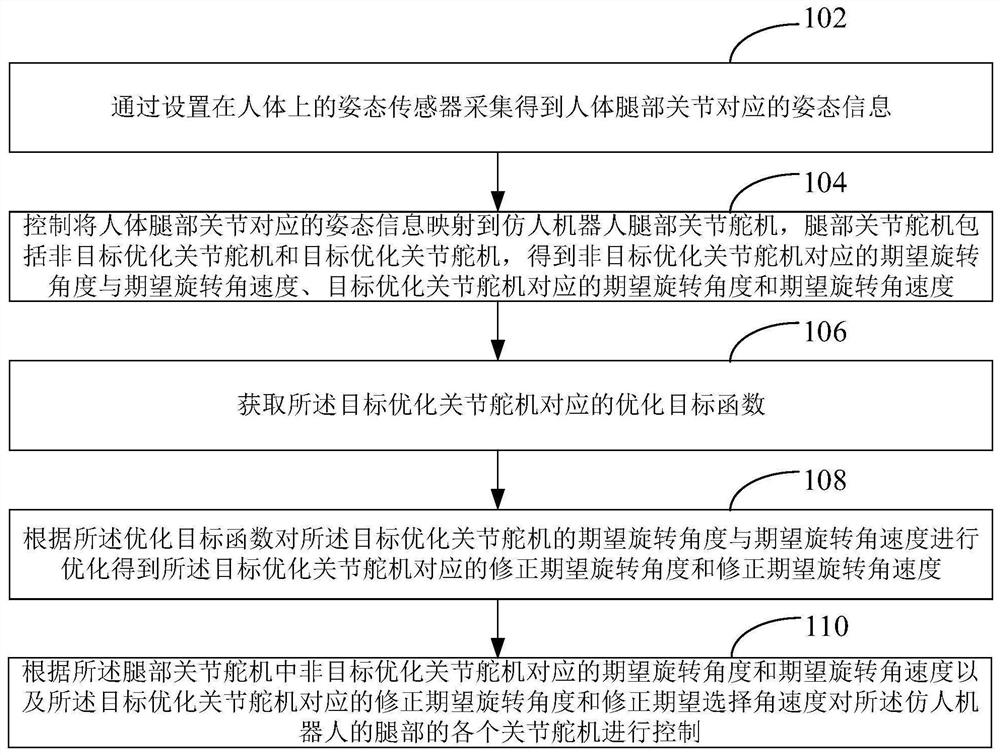
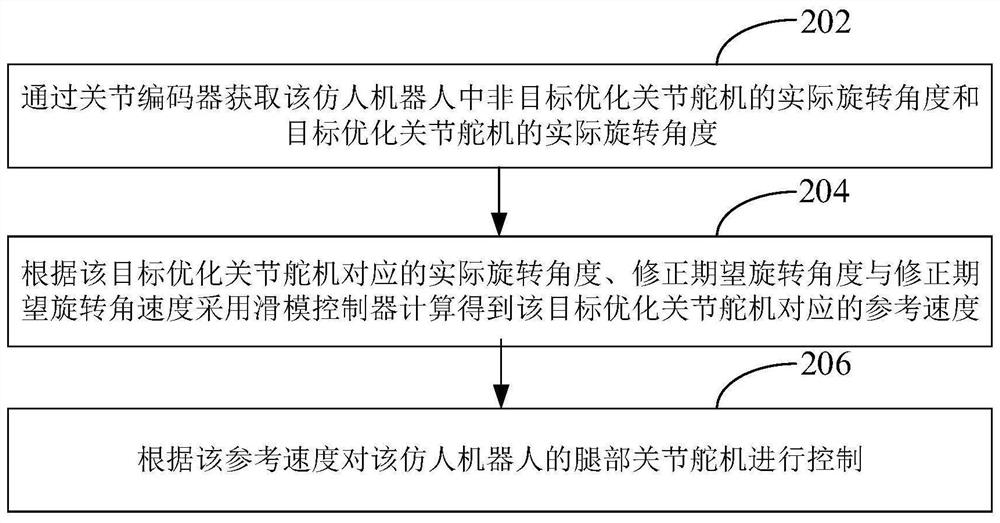
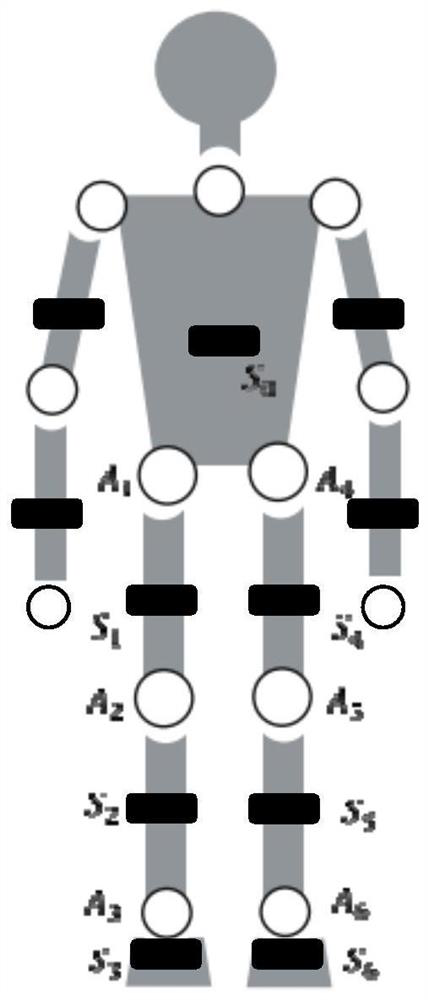
The present application relates to a control method for a humanoid robot, including: mapping posture information corresponding to human leg joints to a humanoid robot leg joint steering gear, and the leg joint steering gear includes a non-target optimized joint steering gear and a target optimized joint steering gear machine, get the expected rotation angle and the expected rotation angular velocity corresponding to the non-target optimized joint steering gear, the expected rotation angle and the expected rotation angular velocity corresponding to the target optimized joint steering gear; establish the optimization objective function corresponding to the target optimized joint steering gear; according to the optimization objective The function optimizes the expected rotation angle and the expected rotational angular velocity of the target optimized joint steering gear to obtain the corrected expected rotational angle and corrected expected rotational angular velocity corresponding to the target optimized joint steering gear; according to the non-target optimized joint servo corresponding expected rotational angle and expected rotational angular velocity And the corrected expected rotation angle and corrected expected rotational angular velocity corresponding to the target optimized joint steering gear control each joint steering gear of the leg of the humanoid robot.
Owner:UBTECH ROBOTICS CORP LTD
A frequency isolation method and device
ActiveCN106559792BSimplify the planning processClear and effective setting principlesNetwork planningData scienceReliability engineering
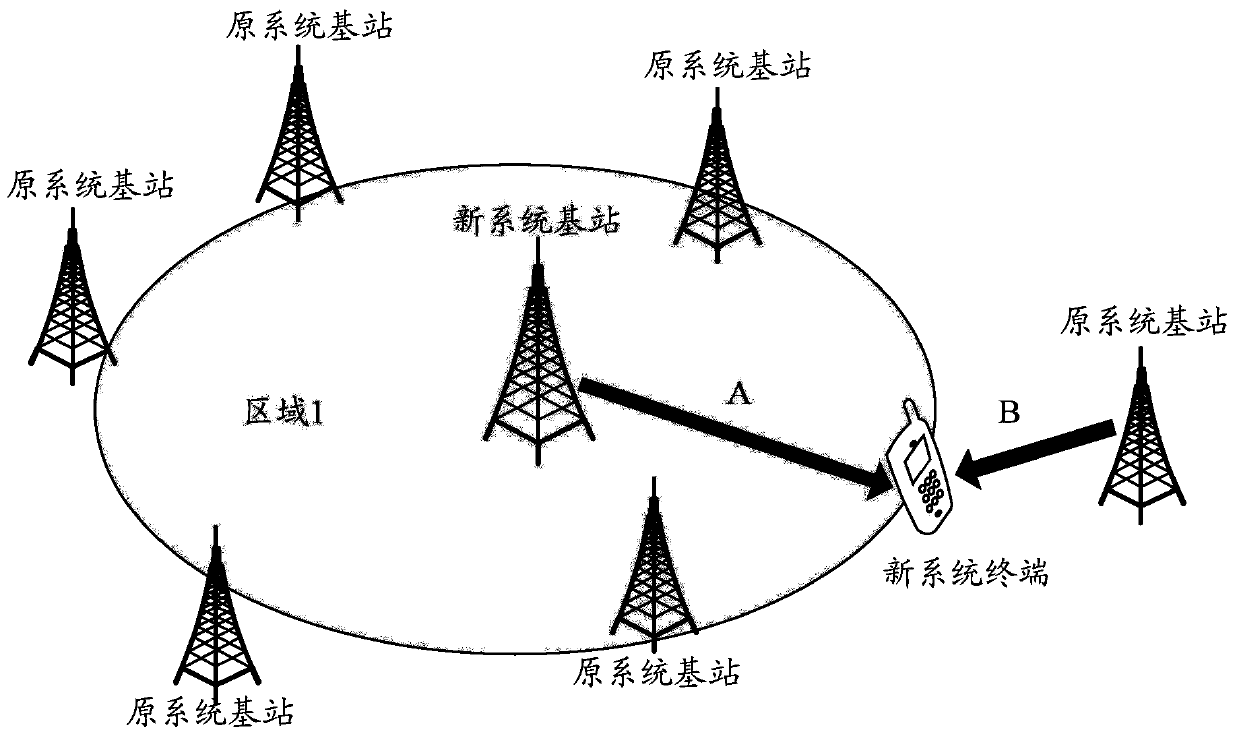
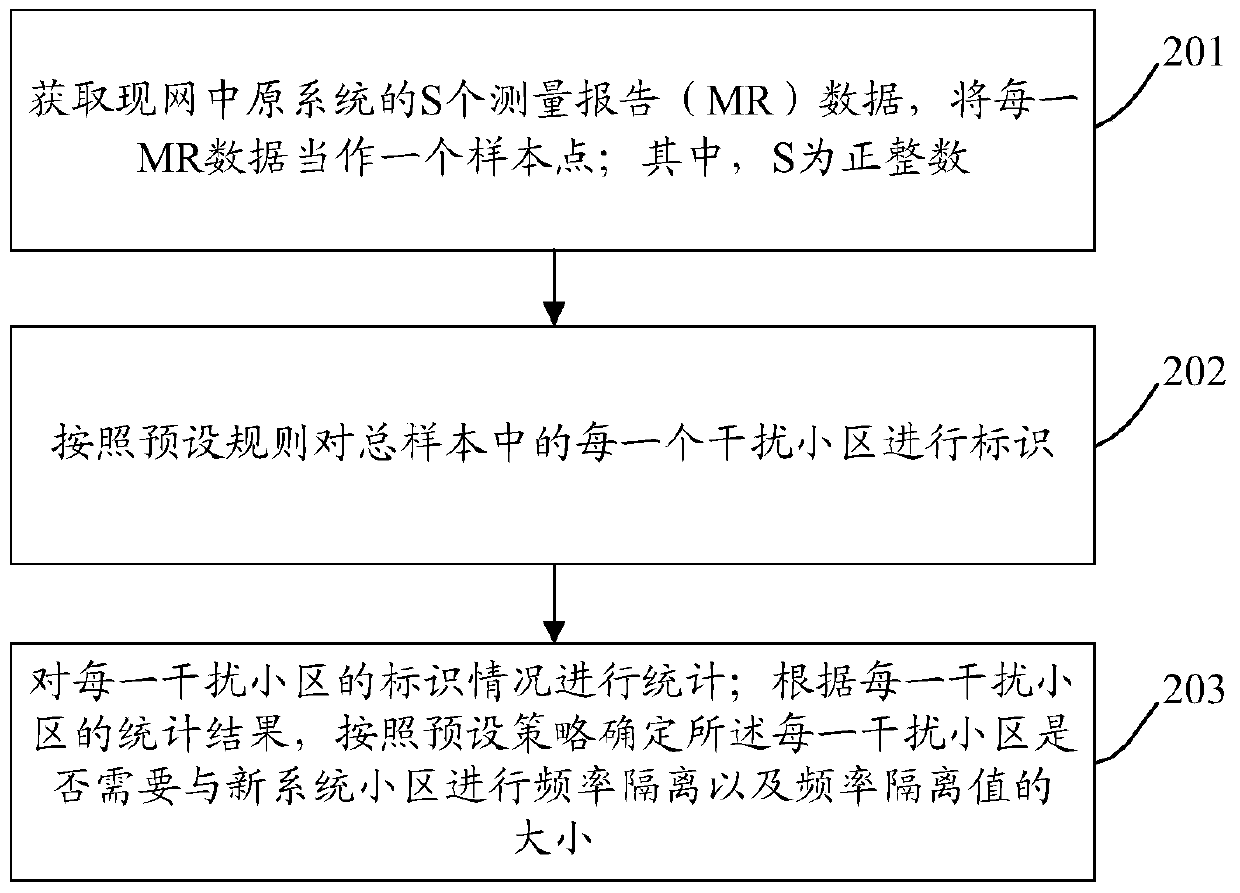
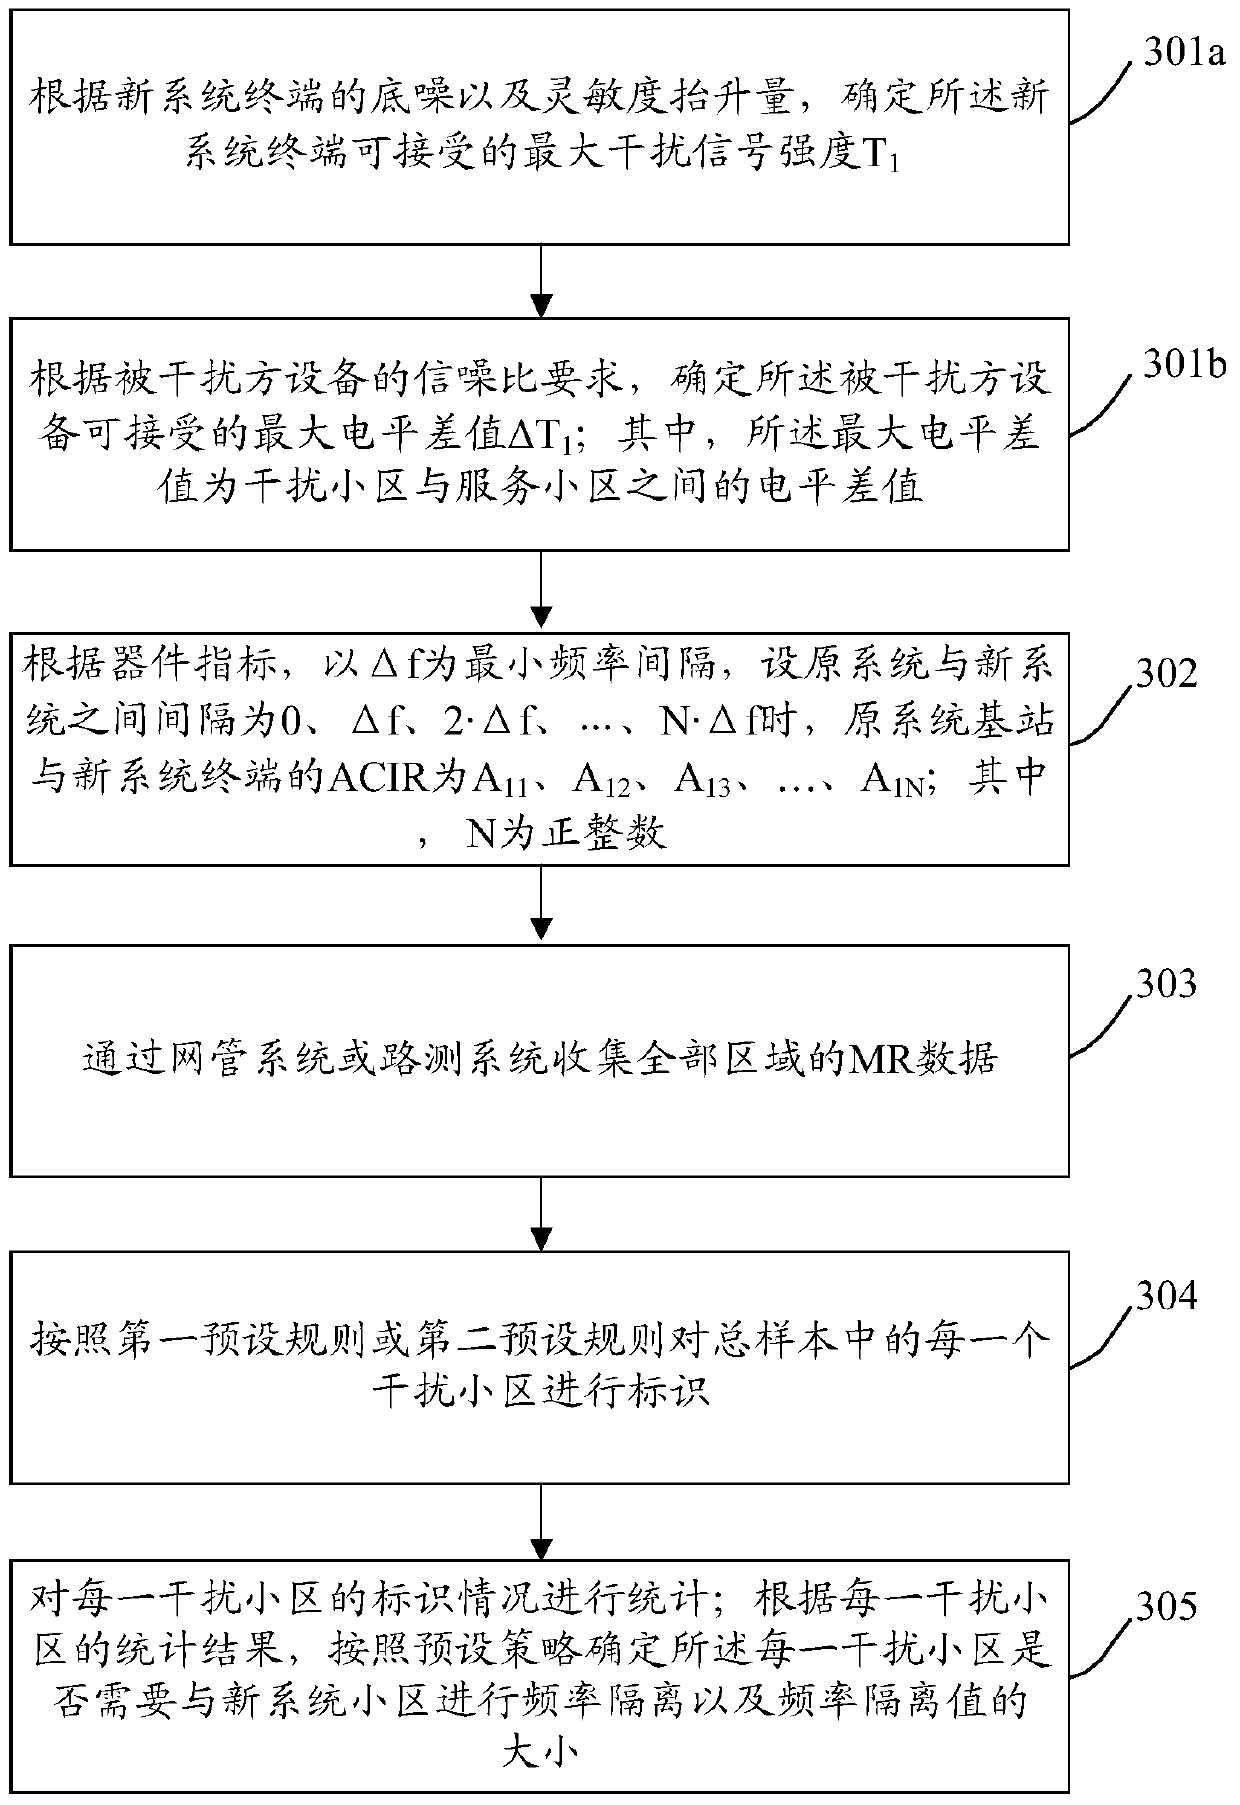
The invention discloses a frequency isolation method comprising: obtaining the data of S measurement reports (MR) of the original system of the current grid; and using the data of each MR as a sampling point wherein S is a positive integer; according to preset rules, carrying out identification to each interfering cell in the total samples; making statistics on the identification condition of each interfering cell; and based on the statistical result of each interfering cell and according to the preset strategy, determining whether each interfering cell needs to be subjected to frequency isolation from a new system cell or not and the frequency isolation value. The invention also discloses a frequency isolation apparatus. With the technical schemes of the invention, it is possible to clearly indicate the choice of a frequency isolation cell and the configuration of the frequency isolation magnitude, simplify the configured network planning procedure and effectively ensure the performances of two systems.
Owner:CHINA MOBILE COMM GRP CO LTD
Method and device for determining space isolation band
ActiveCN106211185ASimplify the planning processGuaranteed performanceNetwork planningCommunications systemFrequency spectrum
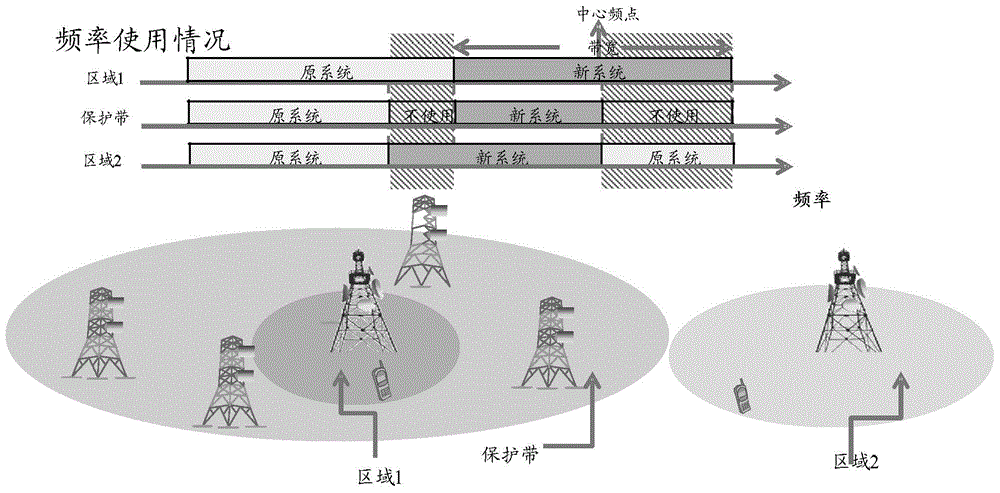
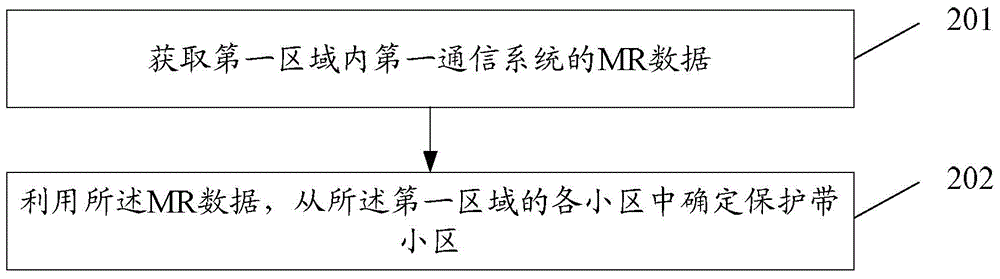
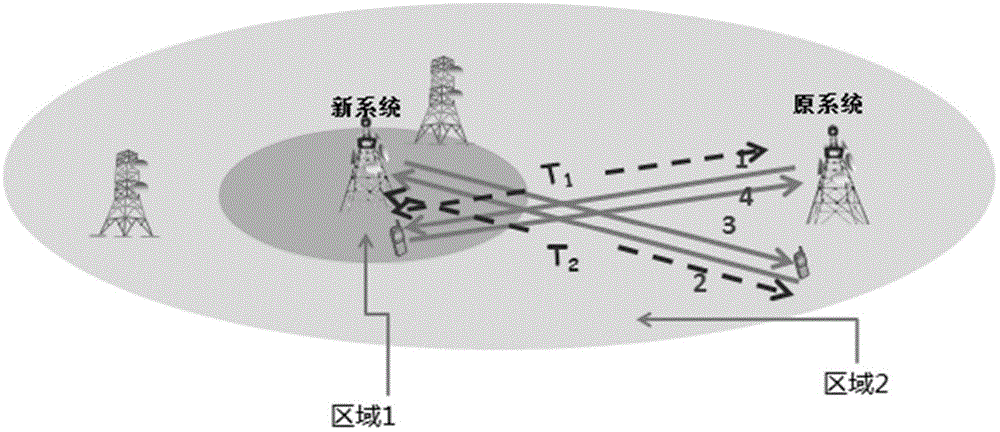
The invention discloses a method for determining a space isolation band. The method comprises the steps of acquiring data of a measurement report (MR) of a first communication system in a first area, wherein the service efficiency of spectrum resources of the first communication system is lower than that of the spectrum resources of the second communication system; and determining a protection band cell from cells of the first area according to the MR data. The invention also simultaneously discloses a device for determining the space isolation band.
Owner:CHINA MOBILE COMM GRP CO LTD
Linear broadside water gauge surveying tool and method
ActiveCN114750892AShorten planning timeReduce repeated horizontal pipeWaterborne vesselsWater resource assessmentStraightedgeMeasurement device
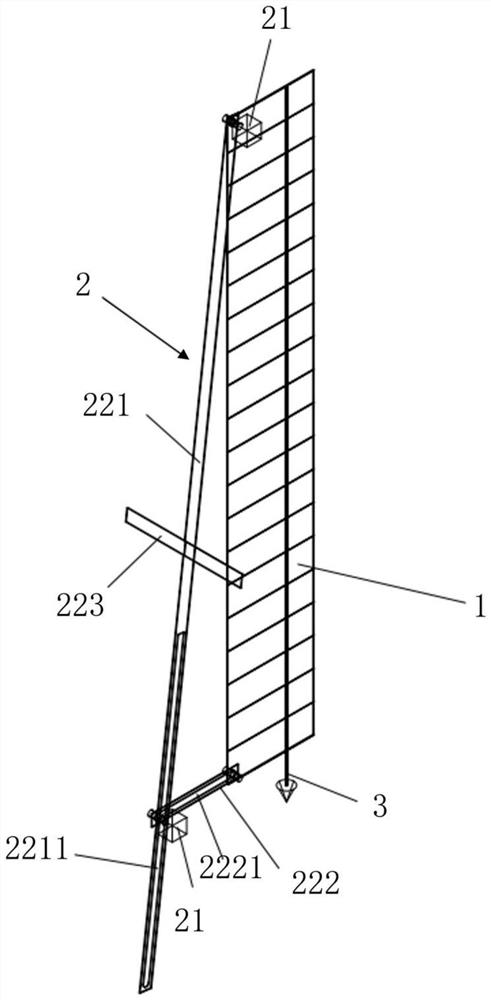
The invention belongs to the technical field of ship construction, and discloses a linear broadside water gauge assignment tool and method.The linear broadside water gauge assignment tool comprises a line drawing plate, an adjusting frame, a measuring device and a straight ruler, and a plurality of horizontal reference lines which are parallel to one another and evenly distributed in sequence are scribed on the line drawing plate; the adjusting frame can be adsorbed on an outer plate of a ship body, the line drawing plate can be mounted on the adjusting frame, and the position of the line drawing plate can be adjusted, so that the horizontal reference line is in the horizontal direction; the measuring device is used for determining whether the horizontal reference line of the adjusting frame is in the horizontal direction or not; the straight ruler is used for being aligned with the horizontal reference line on the line drawing plate so that a water gauge can be drawn on the ship hull plate. The tool is adopted in the linear broadside water gauge assignment method. According to the linear broadside water gauge surveying tool and method, the surveying procedure is simplified, the surveying time is shortened, and only one constructor is used.
Owner:CSSC HUANGPU WENCHONG SHIPBUILDING COMPANY
A Gait Generation and Optimization Method for a Biped Robot
ActiveCN110315543BReduce energy lossAvoid errorsProgramme-controlled manipulatorVehiclesSimulationFinite-state machine
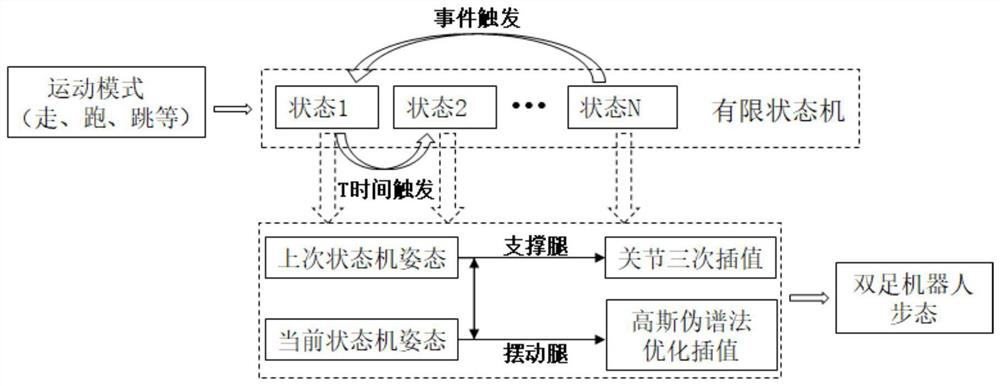
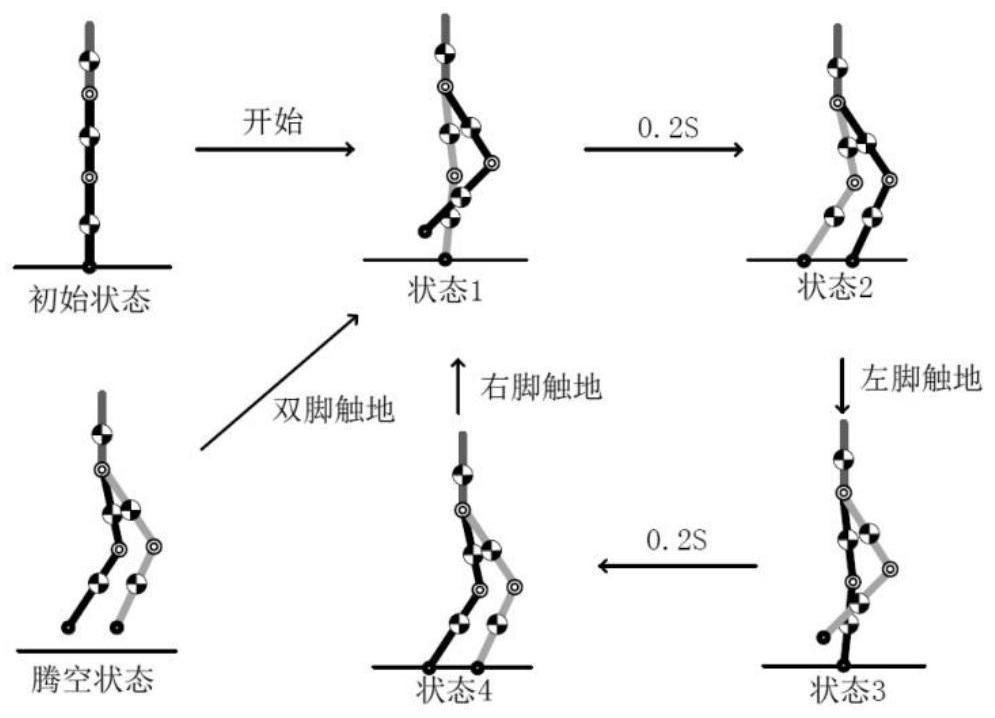
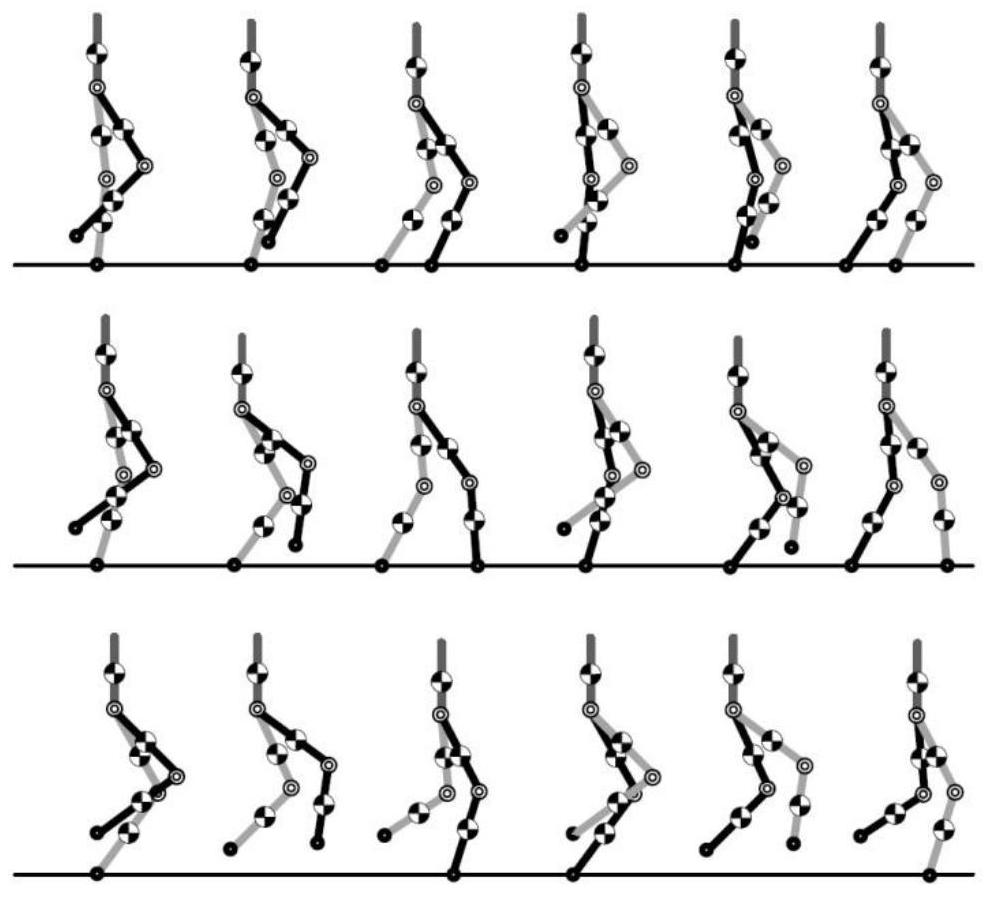
The invention discloses a method for generating and optimizing the gait of a biped robot. In a finite state machine, the gait library of the biped robot is constructed according to the target pose of the state of the biped robot; Switching conditions; in each state switching process, use the joint cubic interpolation method to plan the motion trajectory of the supporting leg, and use the Gaussian pseudospectral method to optimize the motion trajectory of the swinging leg; finally, the finite state machine generates a variety of biped robots For gaits of different motion modes, the biped robot gait generation and optimization method proposed by the present invention does not consider the constraints of ZMP, and biped robots with or without soles can use this method to generate walking trajectories. It makes the planning process simple and operable, and is more suitable for online generation. With a simple control strategy, the biped walking robot can walk stably and complete actions such as walking, running, and jumping.
Owner:BEIJING INSTITUTE OF TECHNOLOGYGY
Humanoid robot control method and device, computer equipment and storage medium
ActiveCN112783043ASimplify the planning processIncrease flexibility and stabilityProgramme controlComputer controlComputer equipmentClassical mechanics
The invention relates to a humanoid robot control method which comprises the steps: mapping posture information corresponding to human leg joints to humanoid robot leg joint steering engines, the leg joint steering engines comprising a non-target optimization joint steering engine and target an optimization joint steering engine; obtaining an expected rotation angle and an expected rotation angular velocity corresponding to the non-target optimization joint steering engine and an expected rotation angle and an expected rotation angular velocity corresponding to the target optimization joint steering engine; establishing an optimization target function corresponding to the target optimization joint steering engine; optimizing the expected rotation angle and the expected rotation angular velocity of the target optimized joint steering engine according to the optimized target function to obtain a corrected expected rotation angle and a corrected expected rotation angular velocity corresponding to the target optimized joint steering engine; and according to the expected rotation angle and the expected rotation angular velocity corresponding to the non-target optimization joint steering engine and the corrected expected rotation angle and the corrected expected rotation angular velocity corresponding to the target optimization joint steering engine, controlling each joint steering engine of the legs of the humanoid robot.
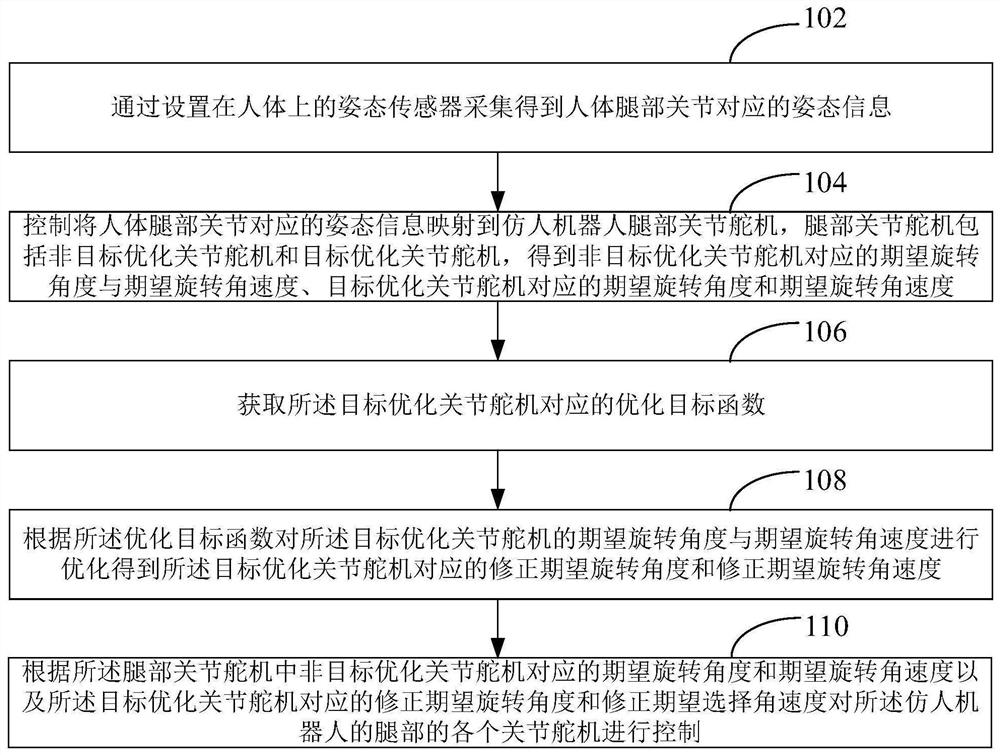
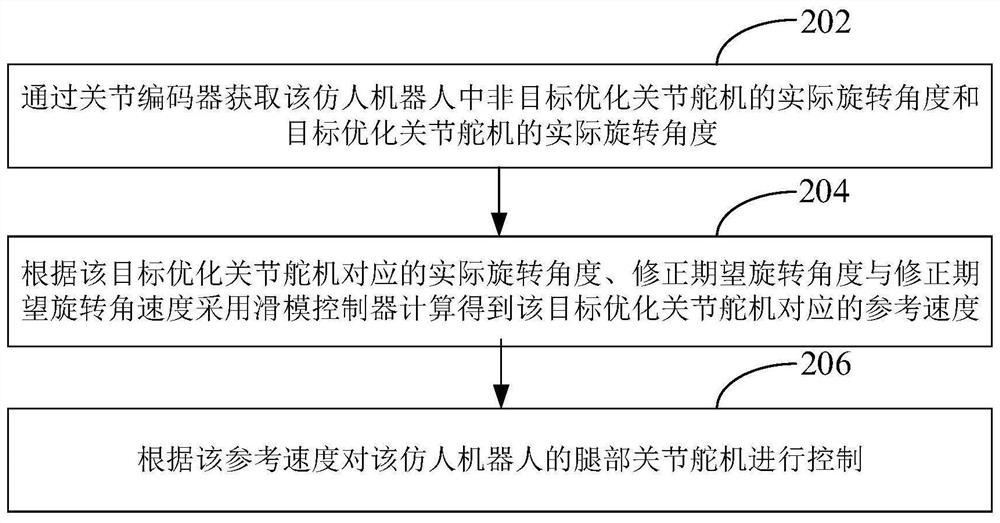
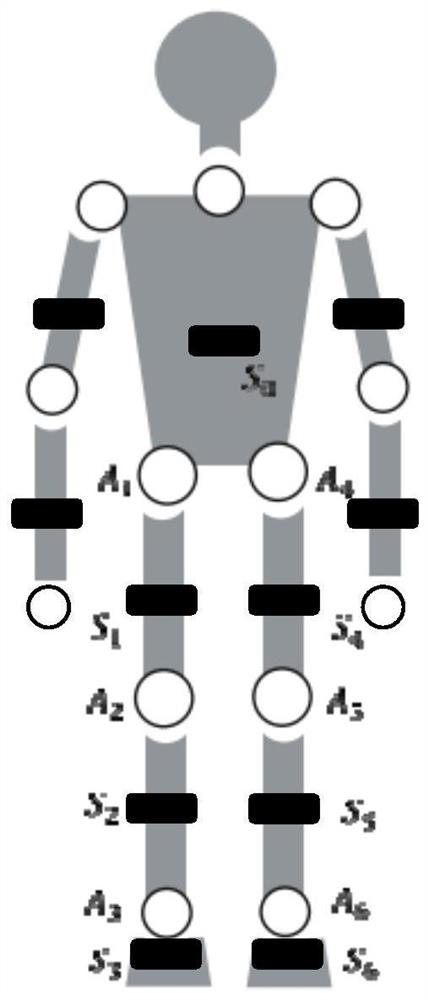
Owner:UBTECH ROBOTICS CORP LTD
Oil-lubricated kinematic module connecting system, mainly the transmission or bearing modules of industrial robot; method of kinematic module lubrication
PendingCN111712358AAchieving a common lifespanExtend your lifeManipulatorGearing detailsThermodynamicsControl system
The oil content of at least two kinematic modules (1) in different axes of the industrial robot is connected by the oil line (2) to the closed circuit of the oil between interconnected kinematic modules (1). In preferred arrangement, the system includes the pump (3) engaged in pushing the oil in the upper-mounted kinematic module (1) and also the filtration device (4) for filtering the oil in thecirculating circuit or in a separate circuit with the oil tank (9). The system may also include at least one diagnostic element (5), for example an oil temperature sensor or an oil pressure sensor oran oil pollution sensor connected to the evaluation unit (6). The evaluation unit (6) can be interconnected with the industrial robot control system, whereby the oil economy is controlled and planneddepending on the actual load of the individual kinematic modules (1). By this arrangement, you can achieve the condition in which the oil from the kinematic module (1) circulates in shared circulationwith the oil from another kinematic module (1), whereas the oil gets purified through the filter device (4) by using the pump (3).
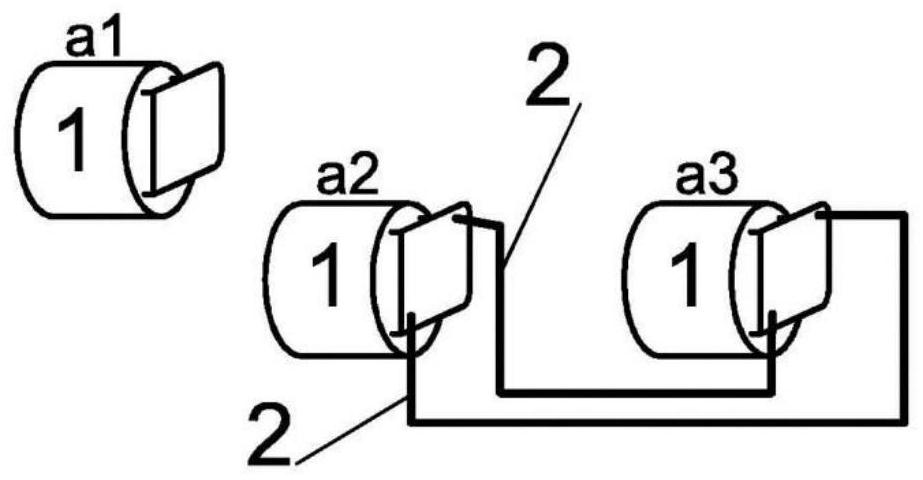
Owner:易洛博特公司
A visual inspection method for part contours based on local tracking path planning
This invention discloses a visual detection method for part contours based on local tracking path planning. The method is as follows: 1. Establish the measurement coordinate system required for visual measurement. 2. Obtain the coarse measurement panoramic contour. Take the circumscribed rectangle of the coarse measurement panoramic contour in the image as the detection area. 3. Preprocessing of the tiled intersection path. 4. Perform local measurement path planning using the A-GSAA algorithm. 5. The probe device performs local tracking measurement according to the optimal measurement path, obtaining n local images; the n local images are stitched together using overlapping parts to extract the contour, obtaining the fine measurement contour. This invention uses A-GSAA to plan the measurement path for the local image shooting points extracted by tiled intersection, and adopts adaptive crossover probability and mutation probability. In the early stage of iteration, the crossover probability and mutation probability are maintained at a high level to promote the generation of new individuals, and the crossover probability and mutation probability are reduced in the later stage of iteration to avoid destroying good individuals.

Owner:HANGZHOU DIANZI UNIV
A train ato fast target curve planning method and system
ActiveCN111469888BSimplify the planning processSolving Planning DifficultiesRailway traffic control systemsSimulationControl theory
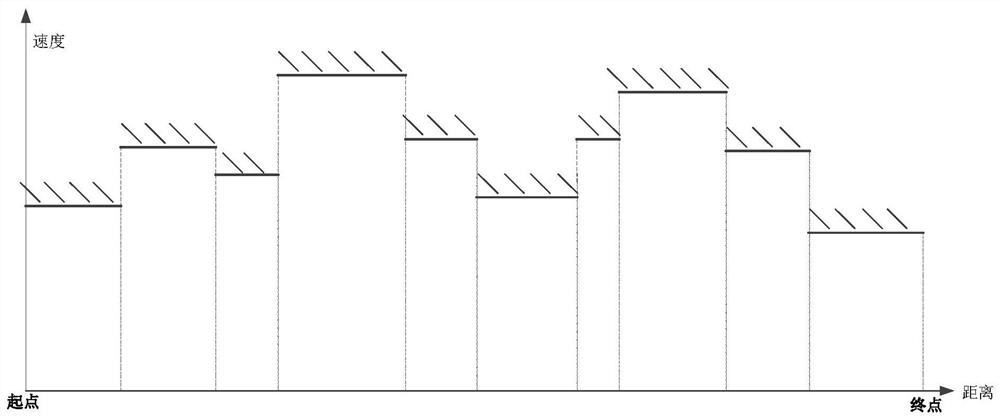
Owner:CSR ZHUZHOU ELECTRIC LOCOMOTIVE RES INST