

Patents
Literature
127results about How to "Easy to initialize" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
PTAM improvement method based on ground characteristics of intelligent robot
InactiveCN104732518ALift strict restrictionsEasy to initializeImage analysisNavigation instrumentsLine searchKey frame
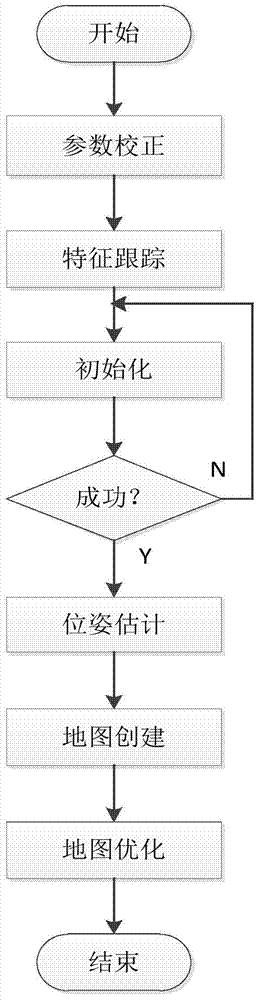
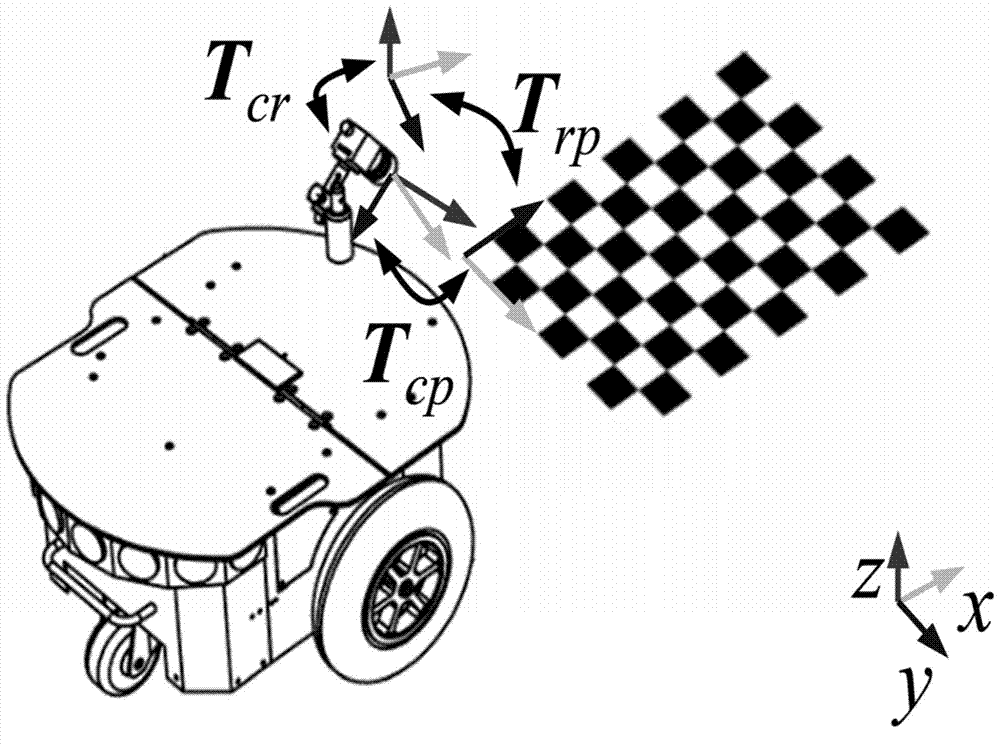
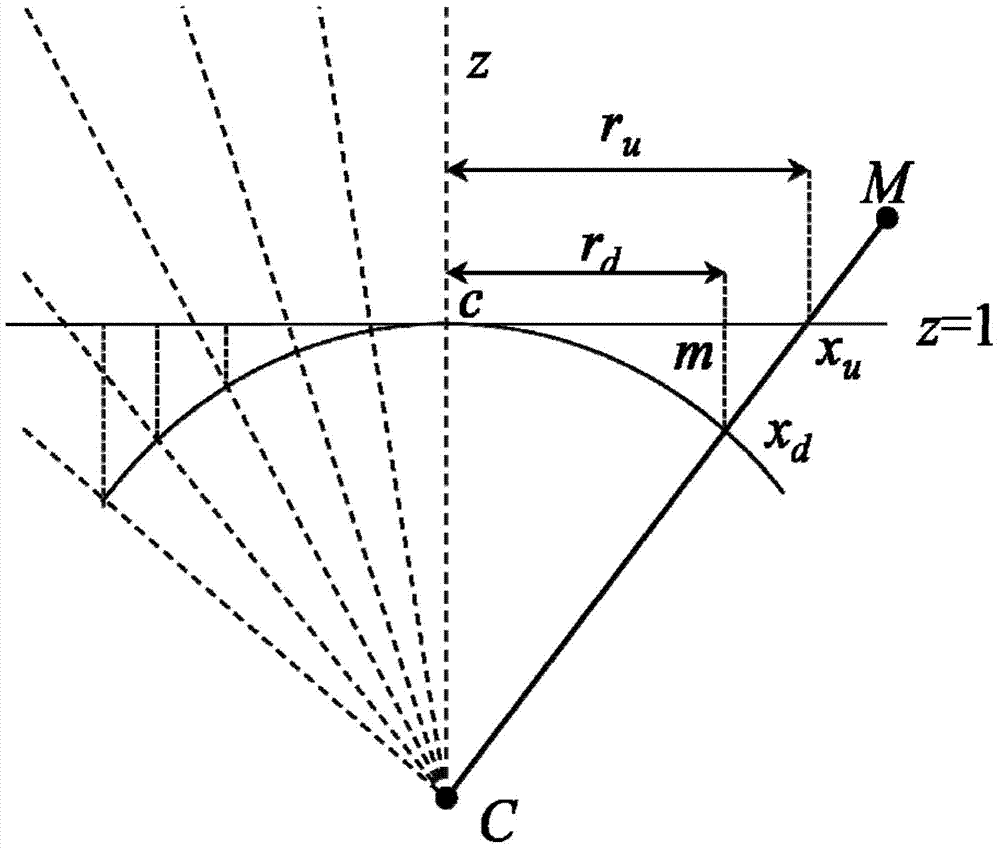
The invention discloses a PTAM improvement method based on ground characteristics of an intelligent robot. The PTAM improvement method based on ground characteristics of the intelligent robot comprises the steps that firstly, parameter correction is completed, wherein parameter correction includes parameter definition and camera correction; secondly, current environment texture information is obtained by means of a camera, a four-layer Gausses image pyramid is constructed, the characteristic information in a current image is extracted by means of the FAST corner detection algorithm, data relevance between corner characteristics is established, and then a pose estimation model is obtained; two key frames are obtained so as to erect the camera on the mobile robot at the initial map drawing stage; the mobile robot begins to move in the initializing process, corner information in the current scene is captured through the camera and association is established at the same time; after a three-dimensional sparse map is initialized, the key frames are updated, the sub-pixel precision mapping relation between characteristic points is established by means of an extreme line searching and block matching method, and accurate re-positioning of the camera is achieved based on the pose estimation model; finally, matched points are projected in the space, so that a three-dimensional map for the current overall environment is established.
Owner:BEIJING UNIV OF TECH
Method and arrangement for arithmetic encoding and decoding binary states and a corresponding computer program and a corresponding computer-readable storage medium
ActiveUS6943710B2Maximum efficiencyEasy to initializeCode conversionImage codingFinite stateProbability estimation
A method and arrangement for arithmetic encoding / decoding is described, wherein the probability estimation is performed by a finite state machine FSM, wherein the generation of N representative states of the FSM is performed offline. Corresponding transition rules are filed in the form of tables. In addition, a pre-quantization of the interval width R to a number of K pre-defined quantization values is carried out. With suitable dimensioning of K and N, this allows the generation of a table containing all K×N combinations of pre-calculated product values R×PLPS for a multiplication-free determination of RLPS. Overall, the result is a good compromise between high coding efficiency and low calculation effort.


Owner:GE VIDEO COMPRESSION LLC
Method of manufacturing operating system master template, method of manufacturing a computer entity and product resulting therefrom, and method of producing a production version of an operating system
InactiveUS7000231B1Maximizing available disk spaceSpace maximizationError detection/correctionDigital computer detailsOperational systemManufacturing systems
A manufacturing system is disclosed for creating a master disk for producing clone copies installed on a plurality of production headless computer entities, said manufacturing system comprising: a build operating system, a set of primary operating system files, a set of emergency operating system files, a set of set-up files, a user interface and a data disk, wherein the manufacturing system creates a master system disk template from the data disk. The master system disk has not less than 3 operating systems, and the master manufacturing system is configured to initialize the master system disk.


Owner:HEWLETT PACKARD DEV CO LP
In-vivo sensing device and method for communicating between imagers and processor thereof
InactiveUS20100013914A1Reduce power consumptionLower Level RequirementsEndoscopesColor television detailsIn vivoComputer science
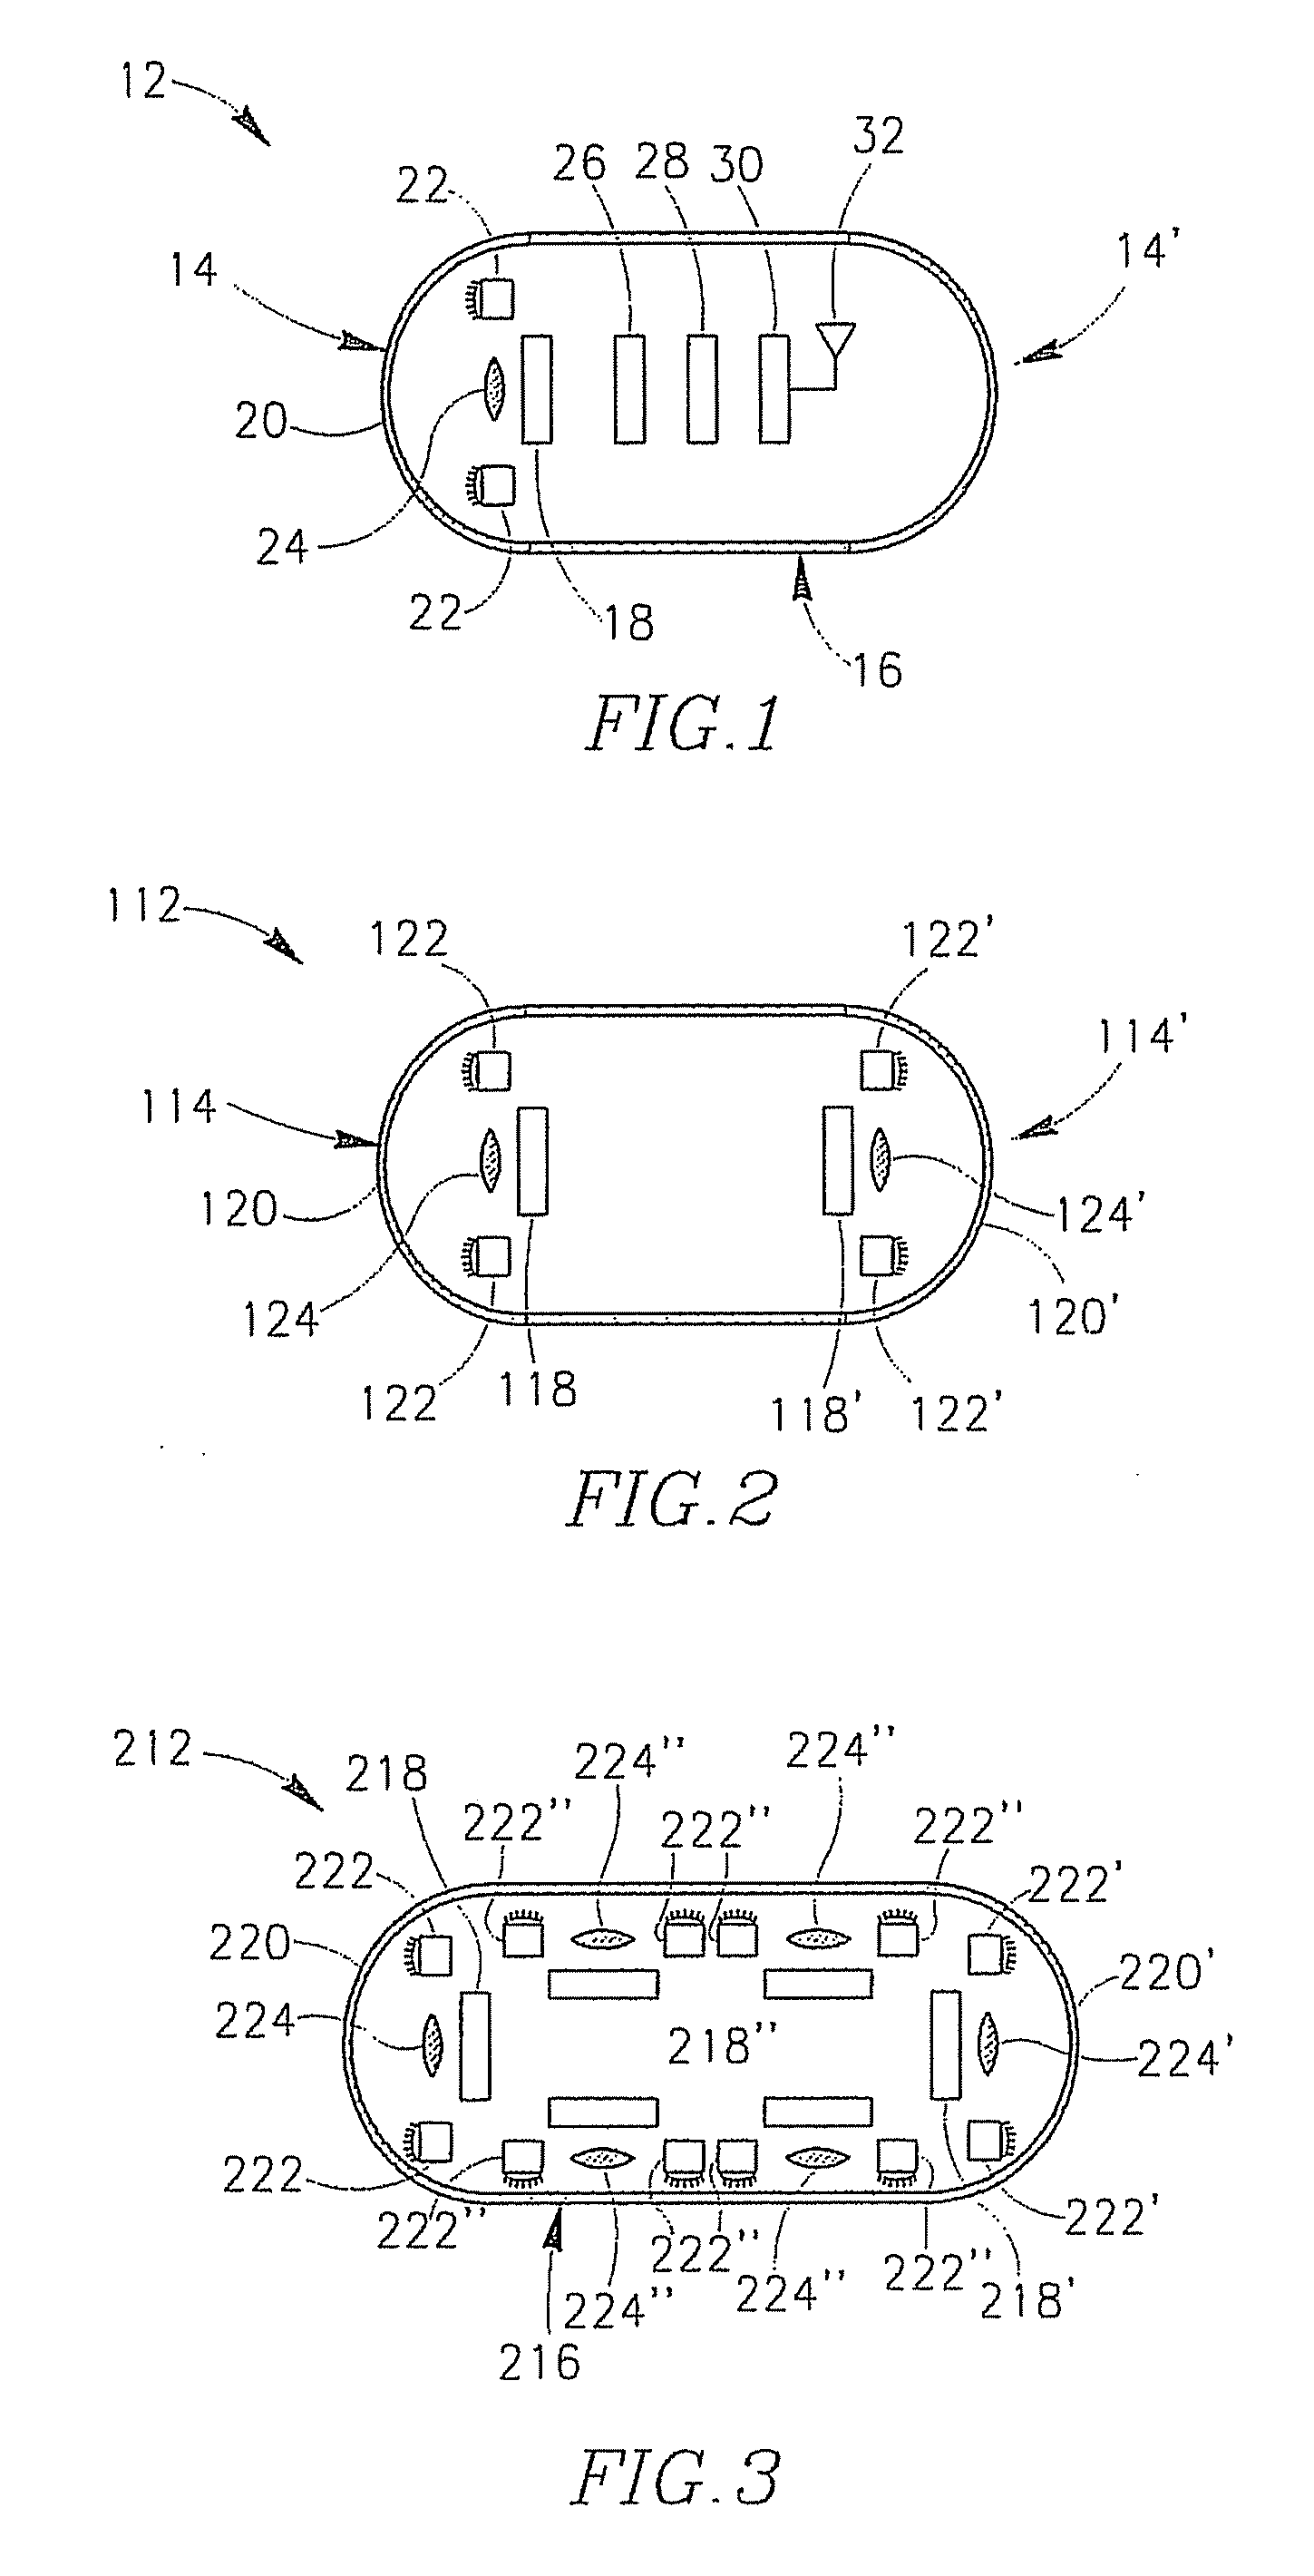
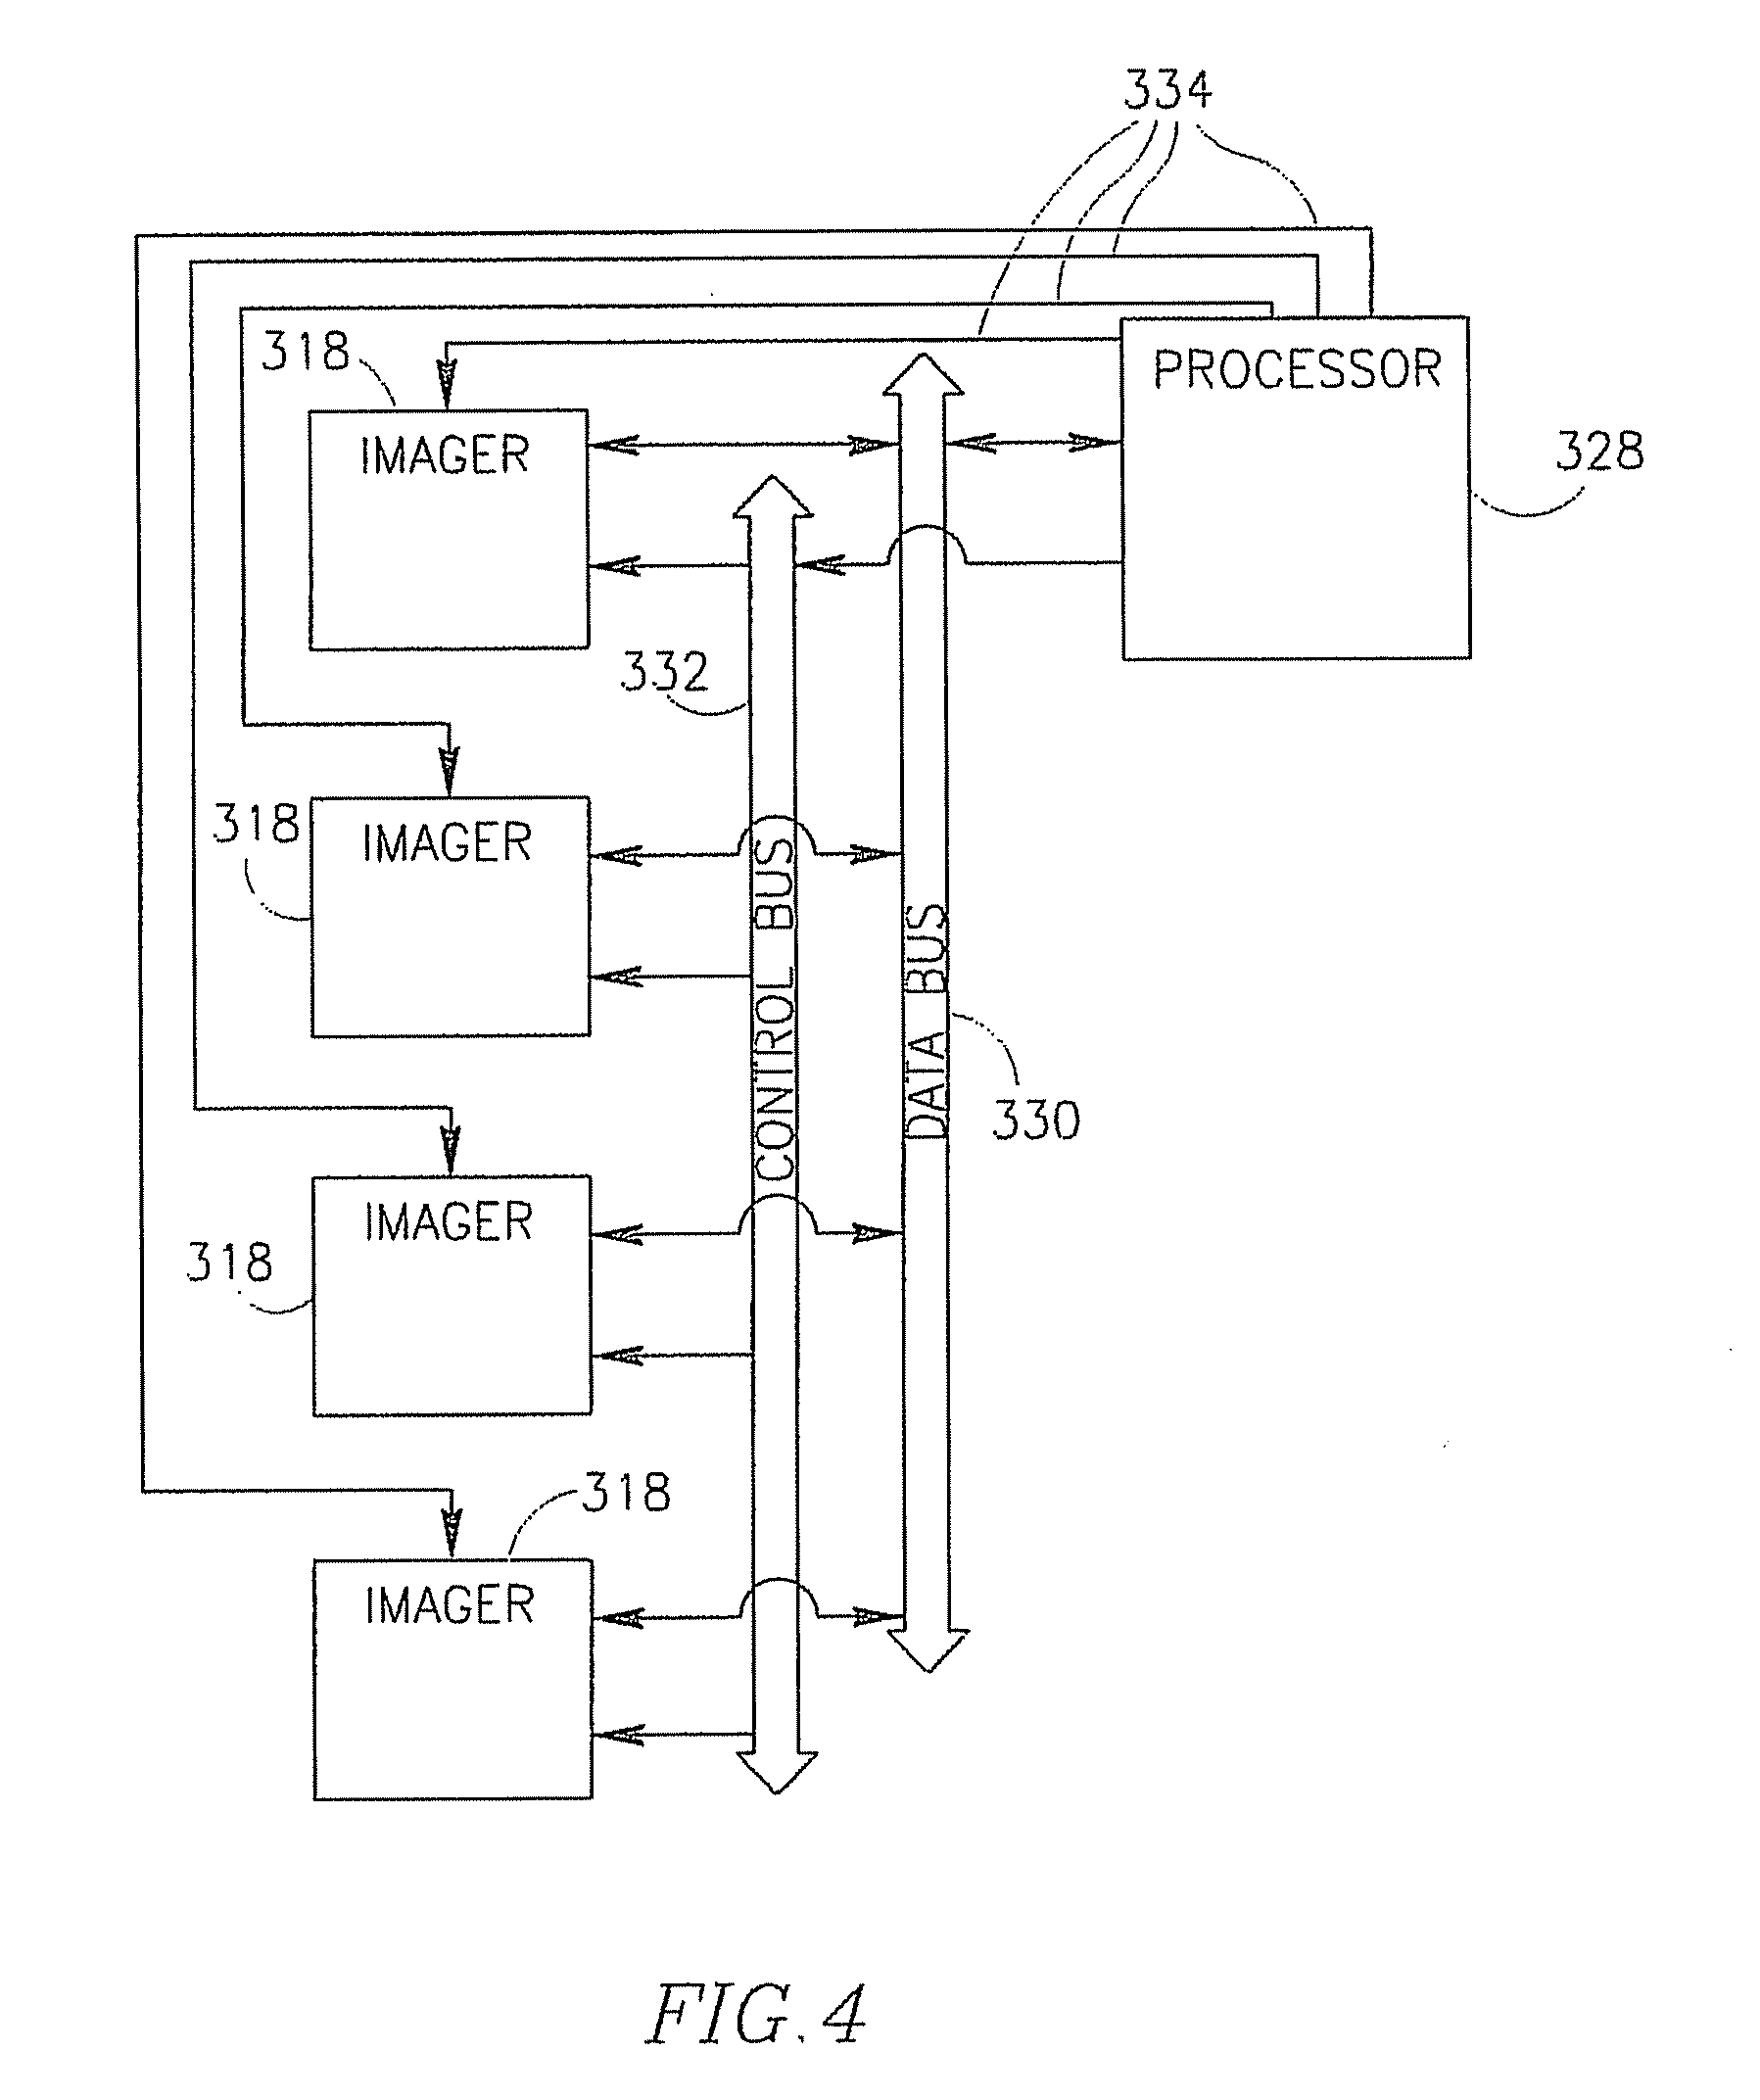
Owner:GIVEN IMAGING LTD
Method and apparatus for operating a network switch in a CPU-less environment
InactiveUS6625146B1Easy to initializeShorten the timeTime-division multiplexGeneral purpose stored program computerComputer hardwareNetwork switch
A method and apparatus are disclosed for operating a network switch without the use of a CPU. A control interface is used to connect the network switch to the external CPU. The control interface generates an initialization signal indicative of the absence of a CPU. Upon receiving the initialization signal, an internal rules checker initializes the network switch. The internal rules checker will then begin receiving data frames and forwarding them to the appropriate network stations based on a source address and destination address contained in the data frames.


Owner:GLOBALFOUNDRIES INC
Method of matching image features with reference features and integrated circuit therefor
ActiveUS20150049955A1Easy to initializeImprove performanceCharacter and pattern recognitionStill image data queryingImaging FeatureSimilarity measure
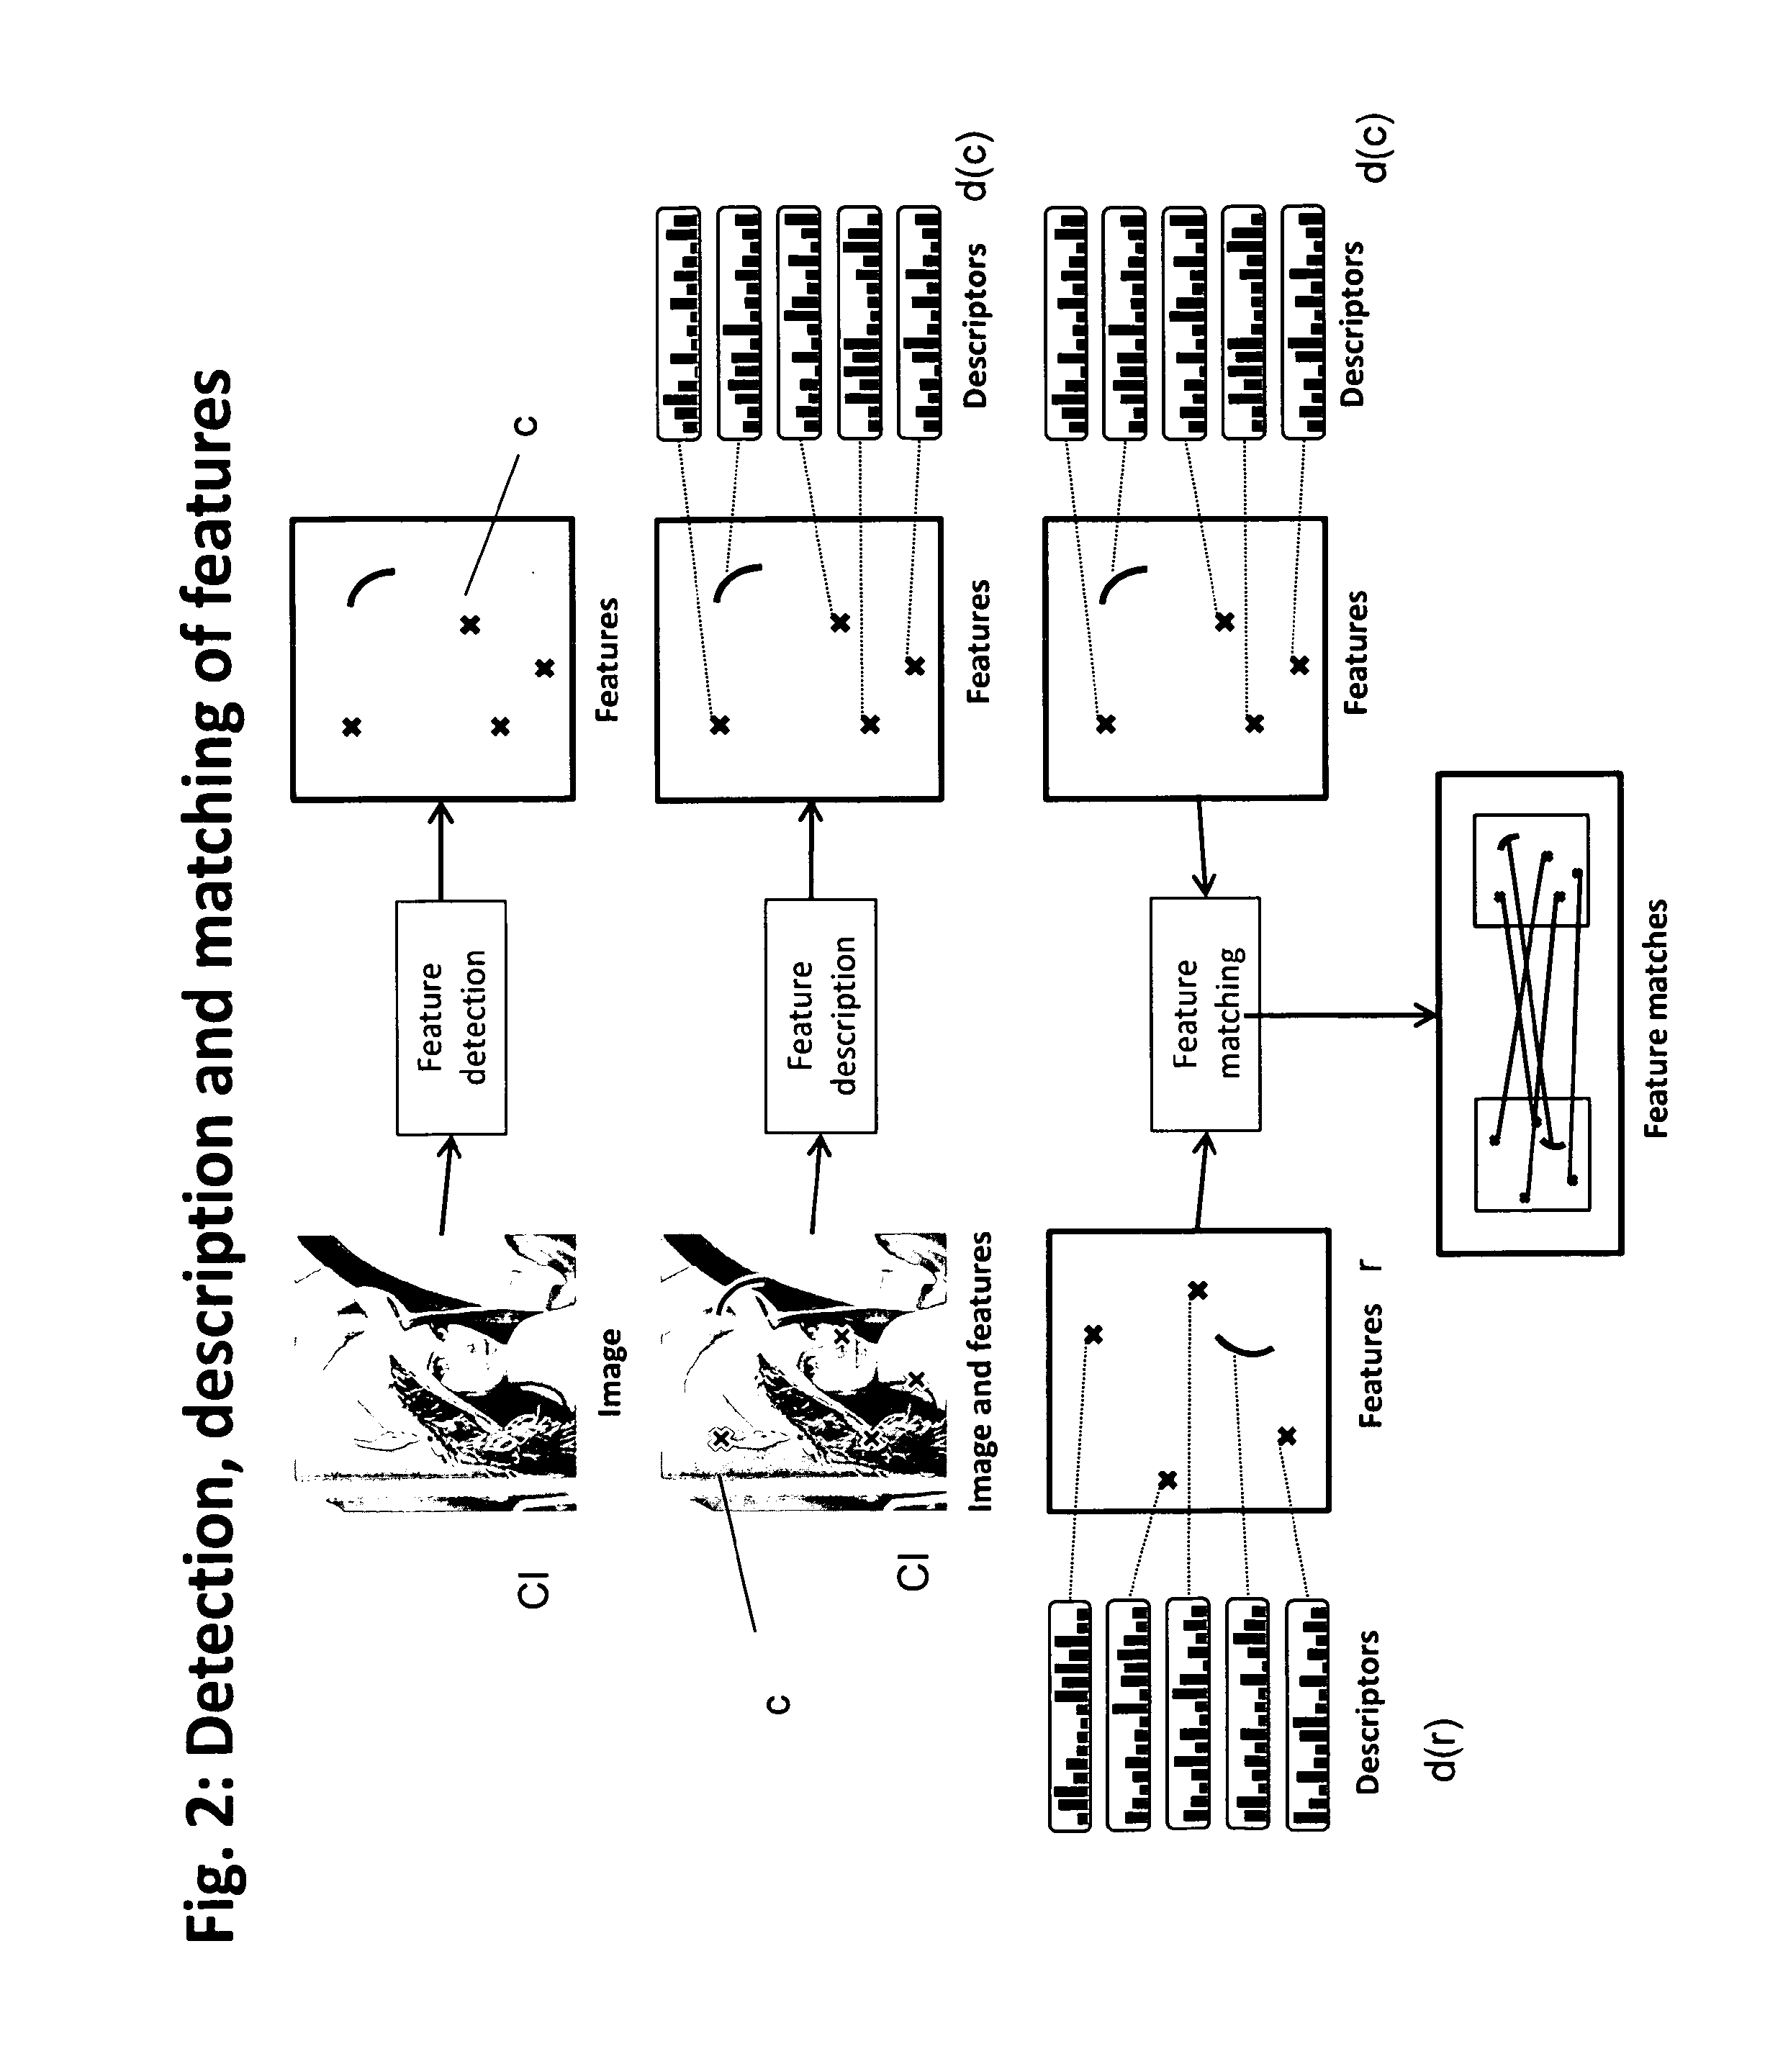
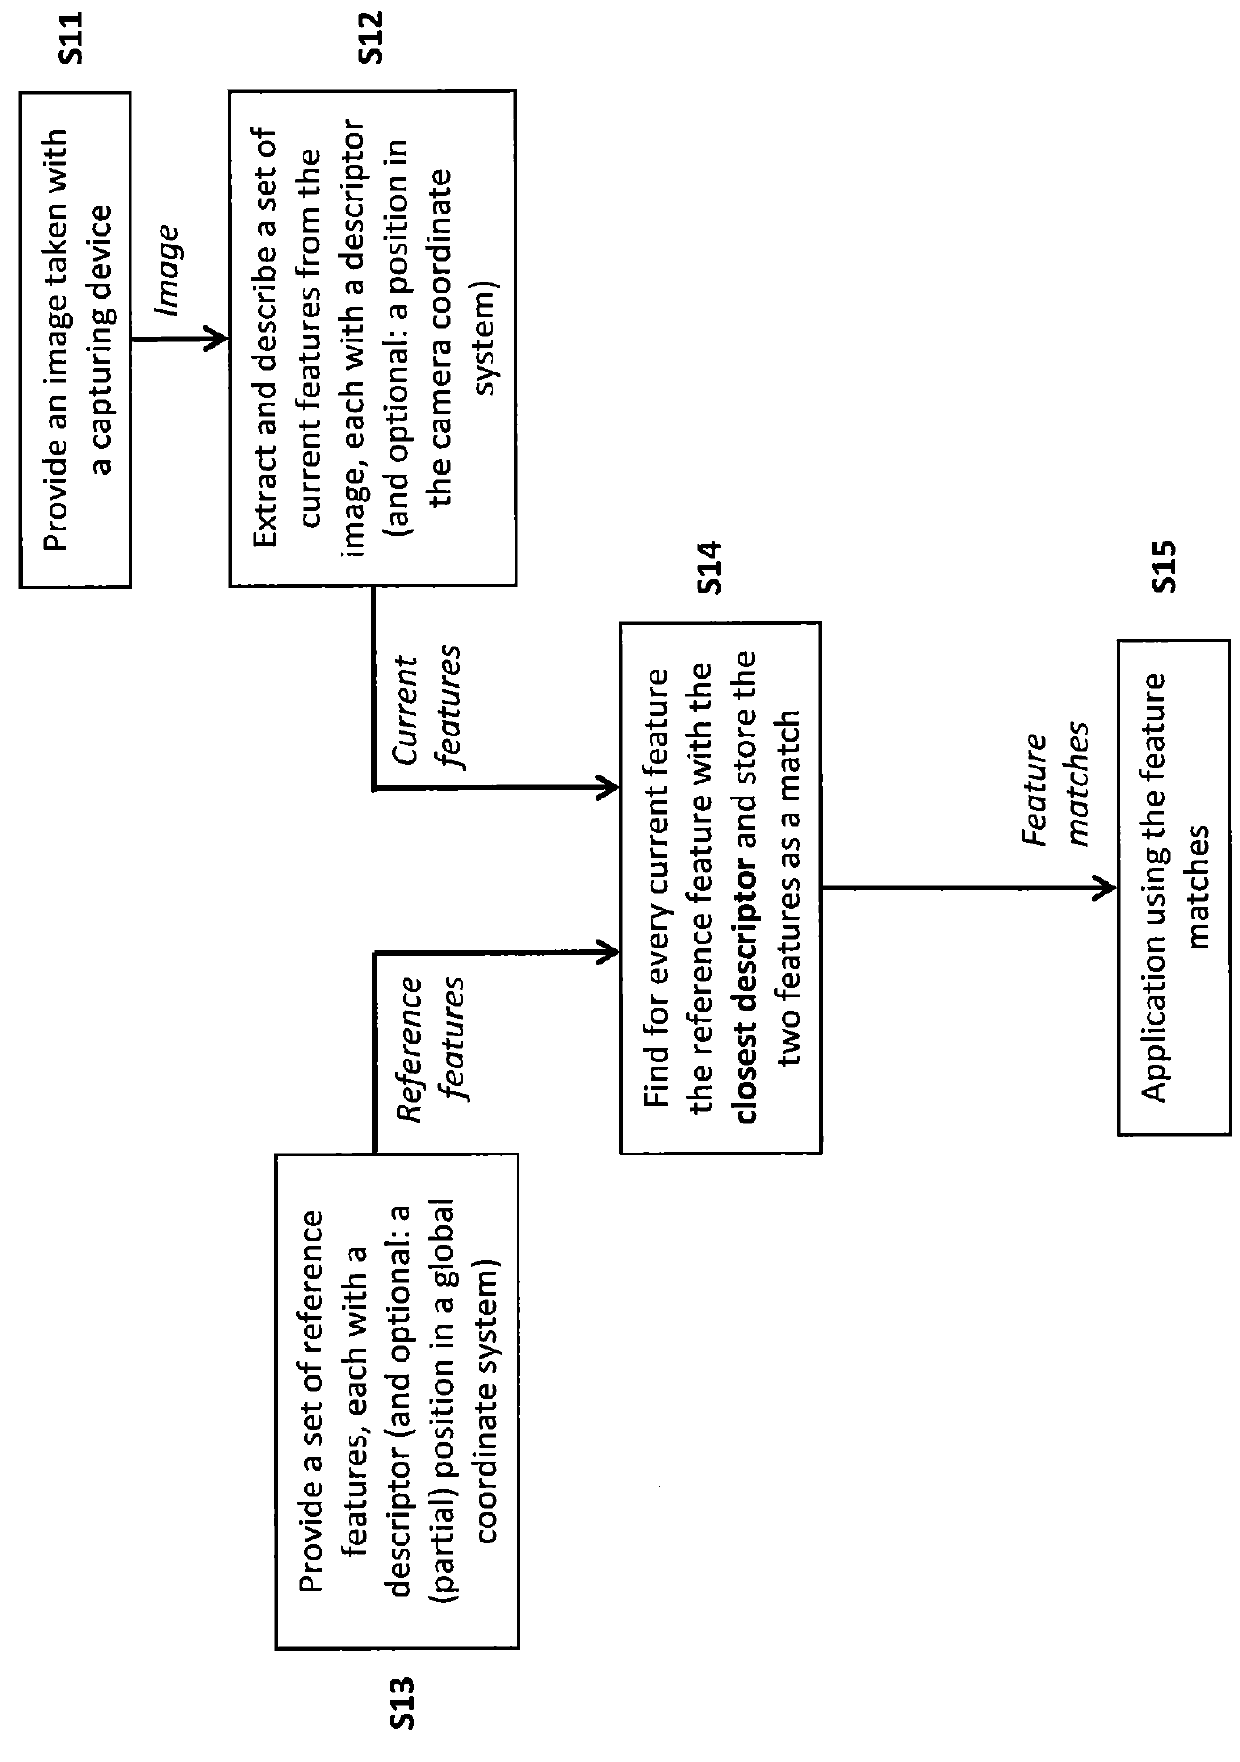
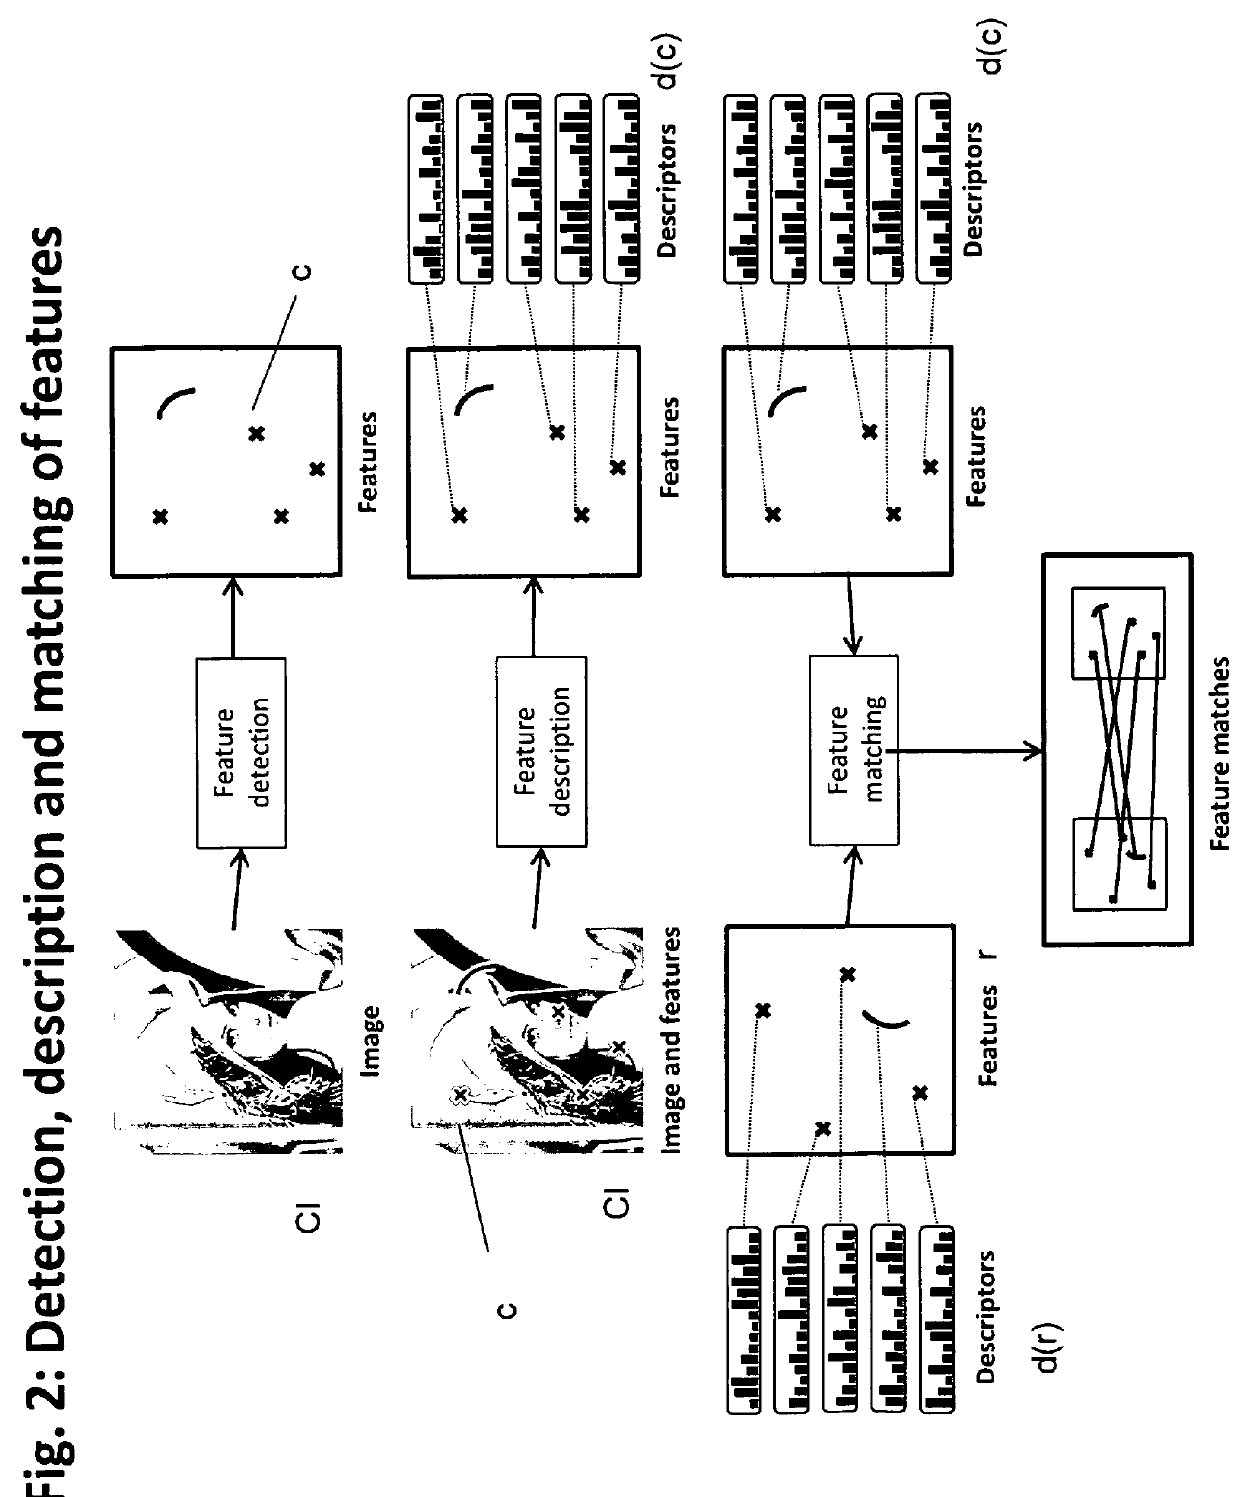
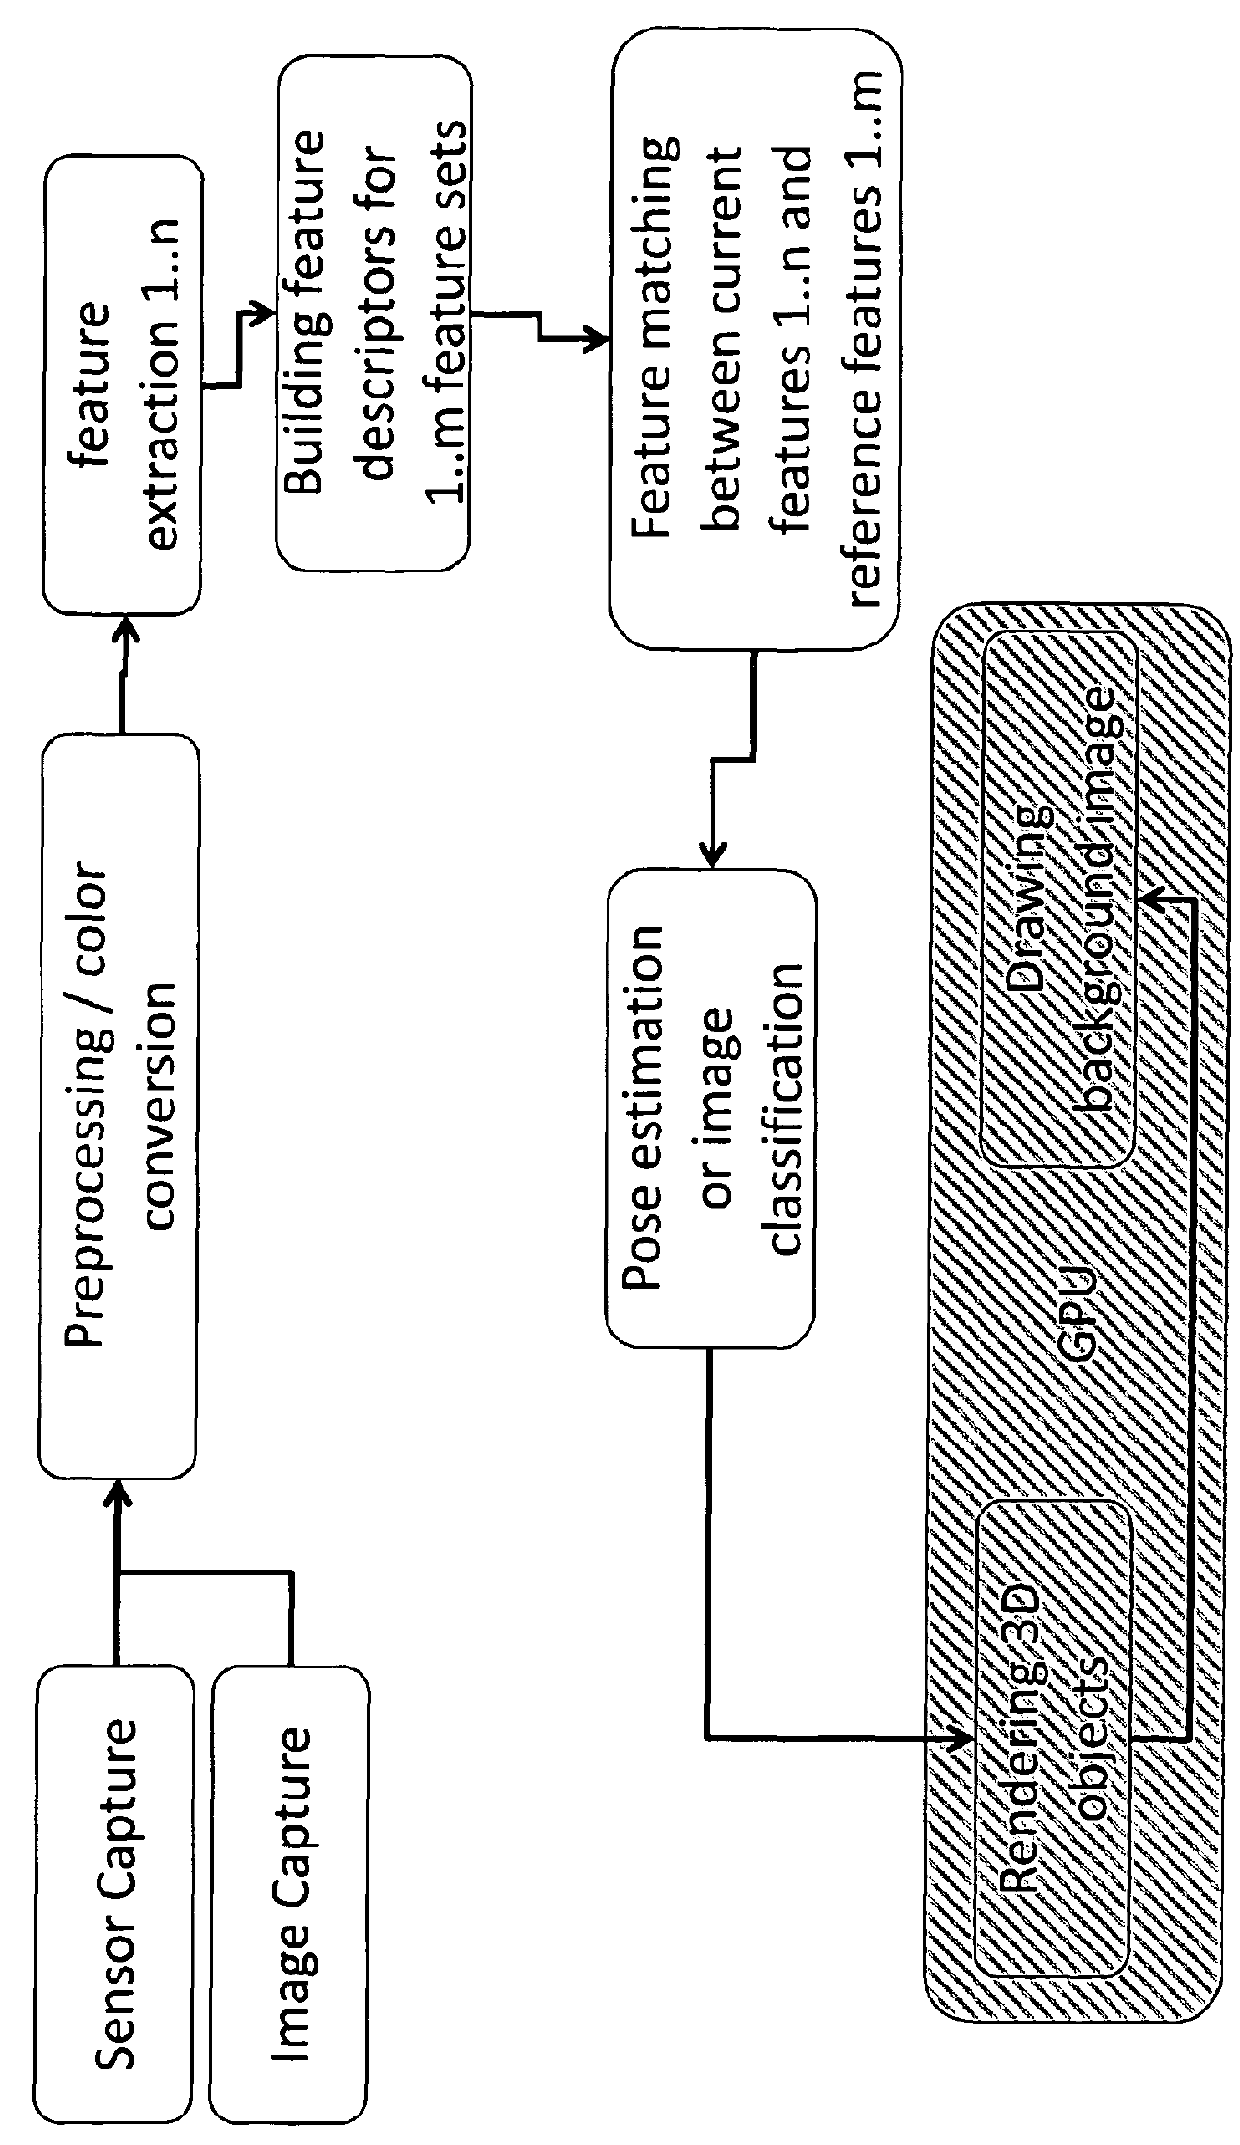
The invention is related to a method of matching image features with reference features, comprising the steps of providing a current image captured by a capturing device, providing reference features (r), wherein each of the reference features comprises at least one reference feature descriptor (d(r)), determining current features (c) in the current image and associating with each of the current features at least one respective current feature descriptor (d(c)), and matching the current features with at least some of the reference features by determining a respective similarity measure (D(c, r)) between each respective current feature descriptor (d(c)) and each respective reference feature descriptor (d(r)). According to the invention, the determination of the similarity measure is performed on an integrated circuit by hardwired logic or configurable logic which processes logical functions for determining the similarity measure. The invention is also concerned with an integrated circuit for matching of image features with reference features.
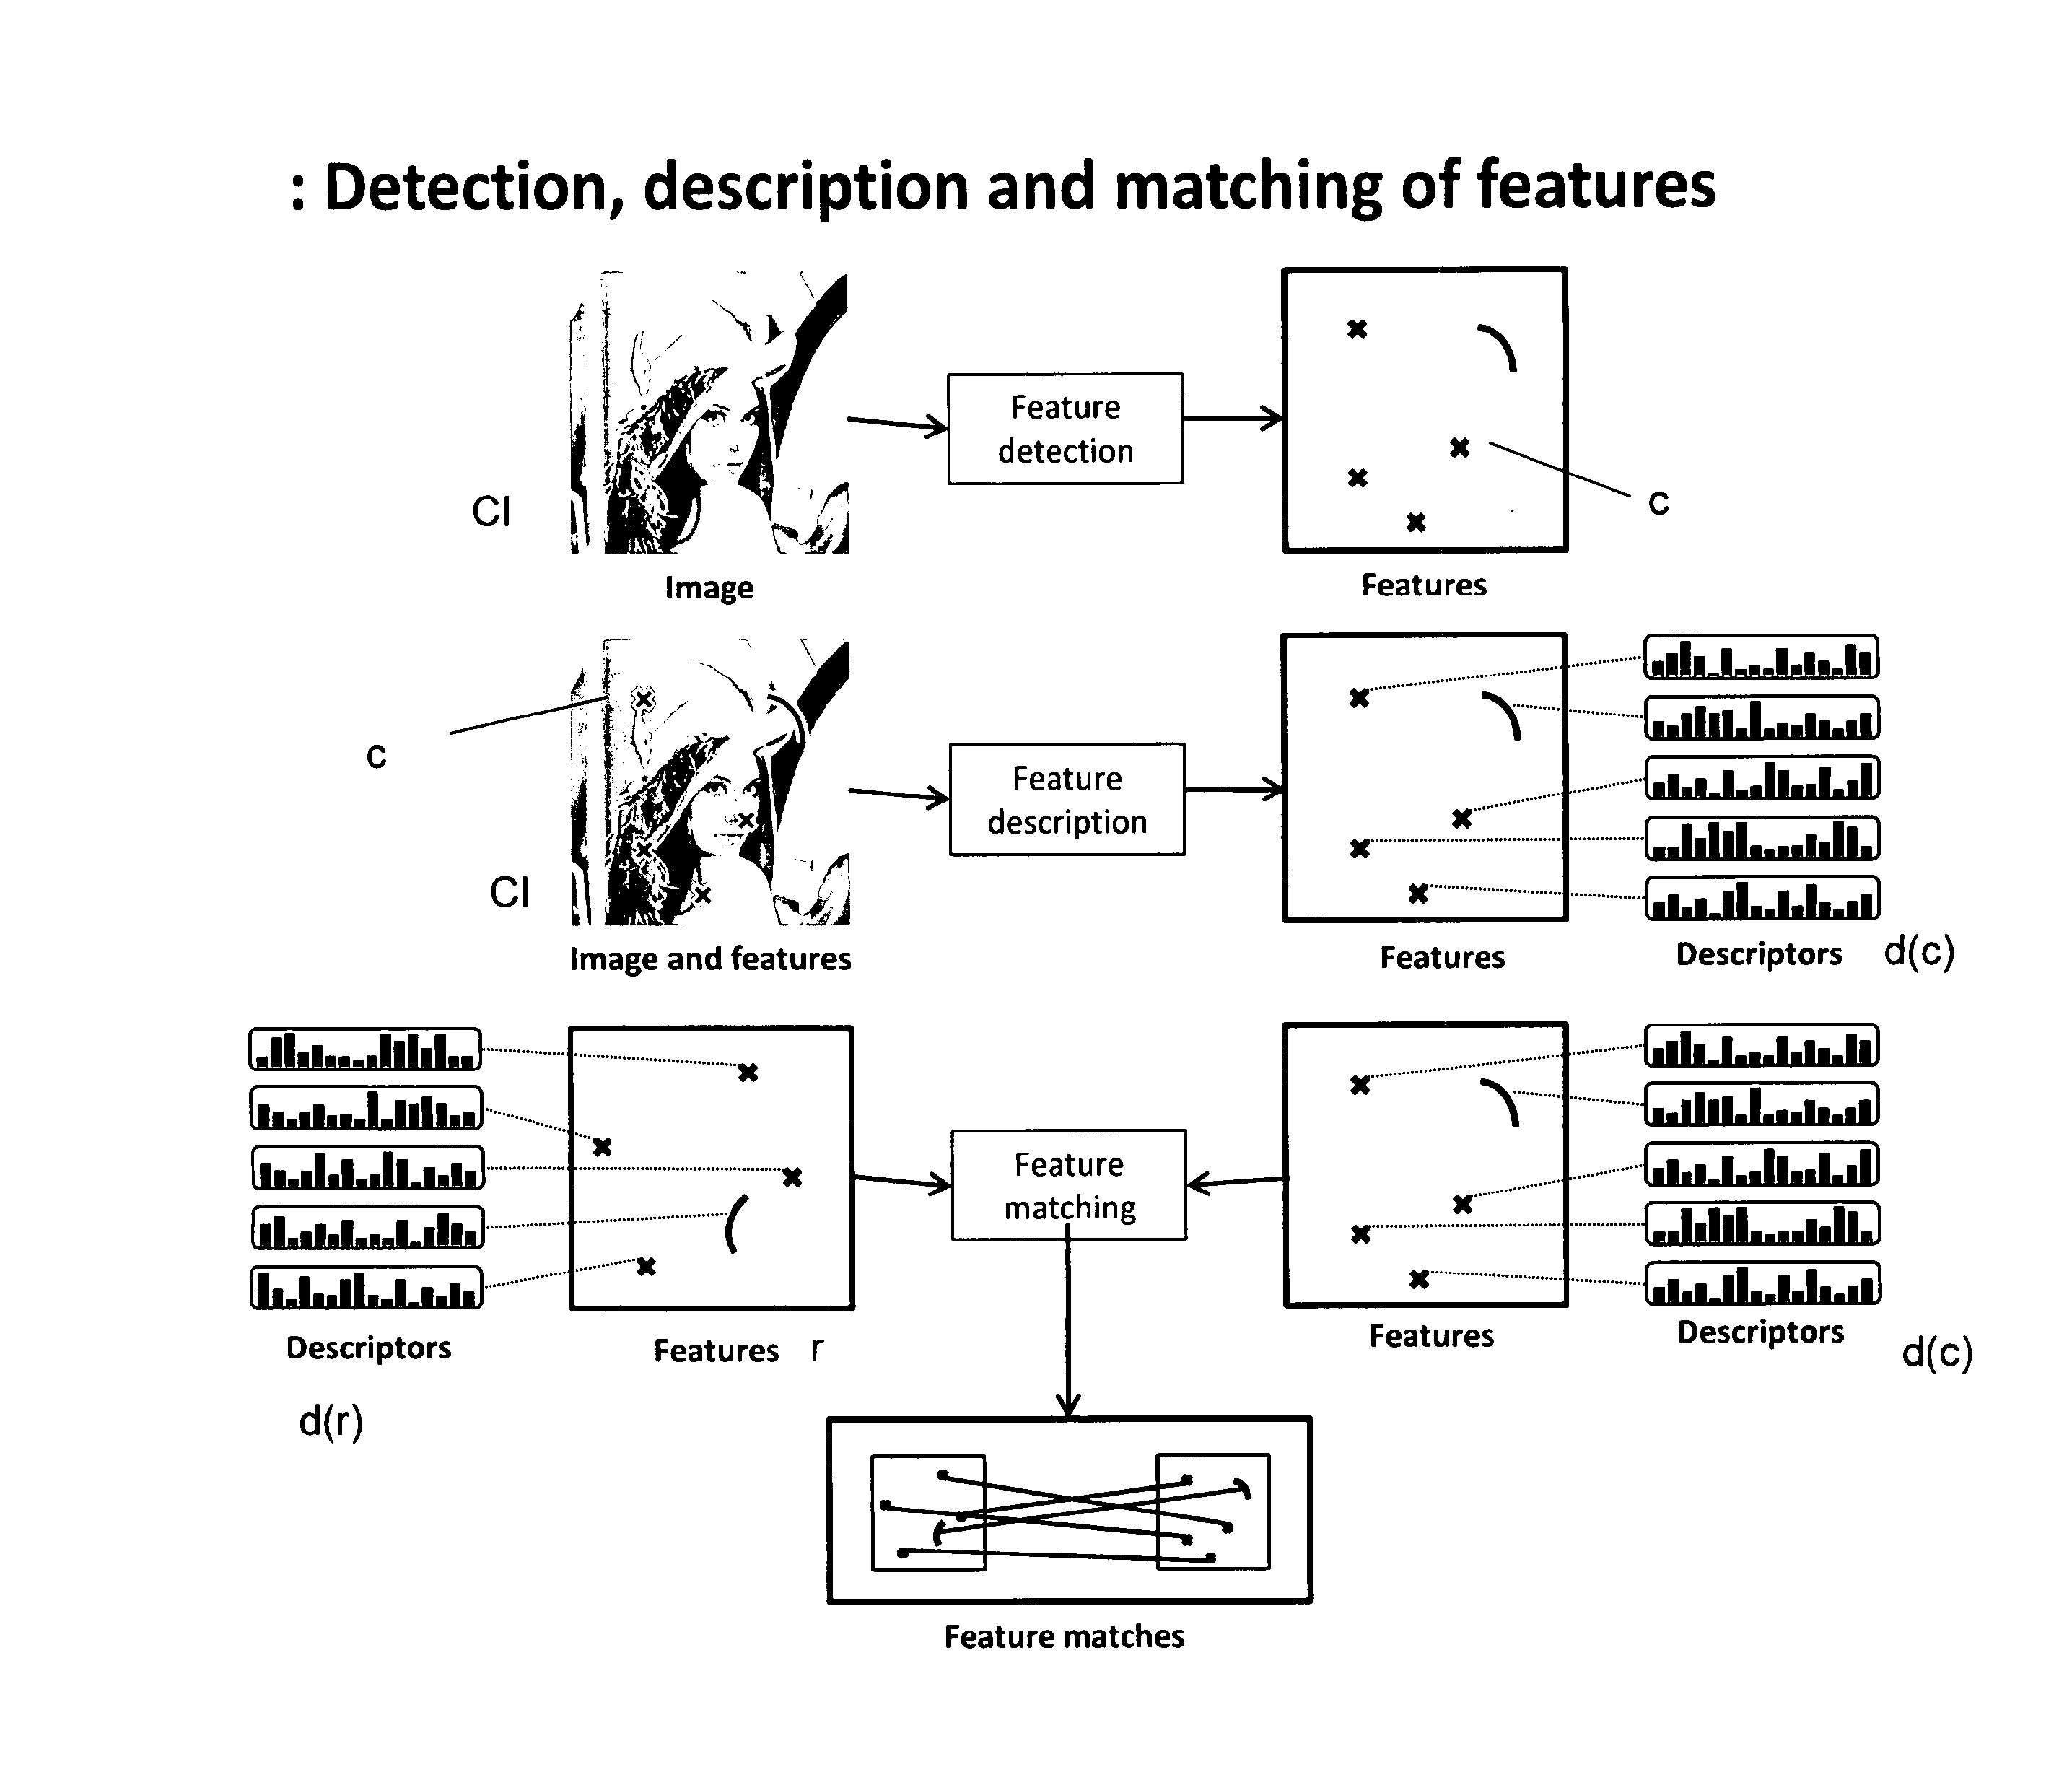
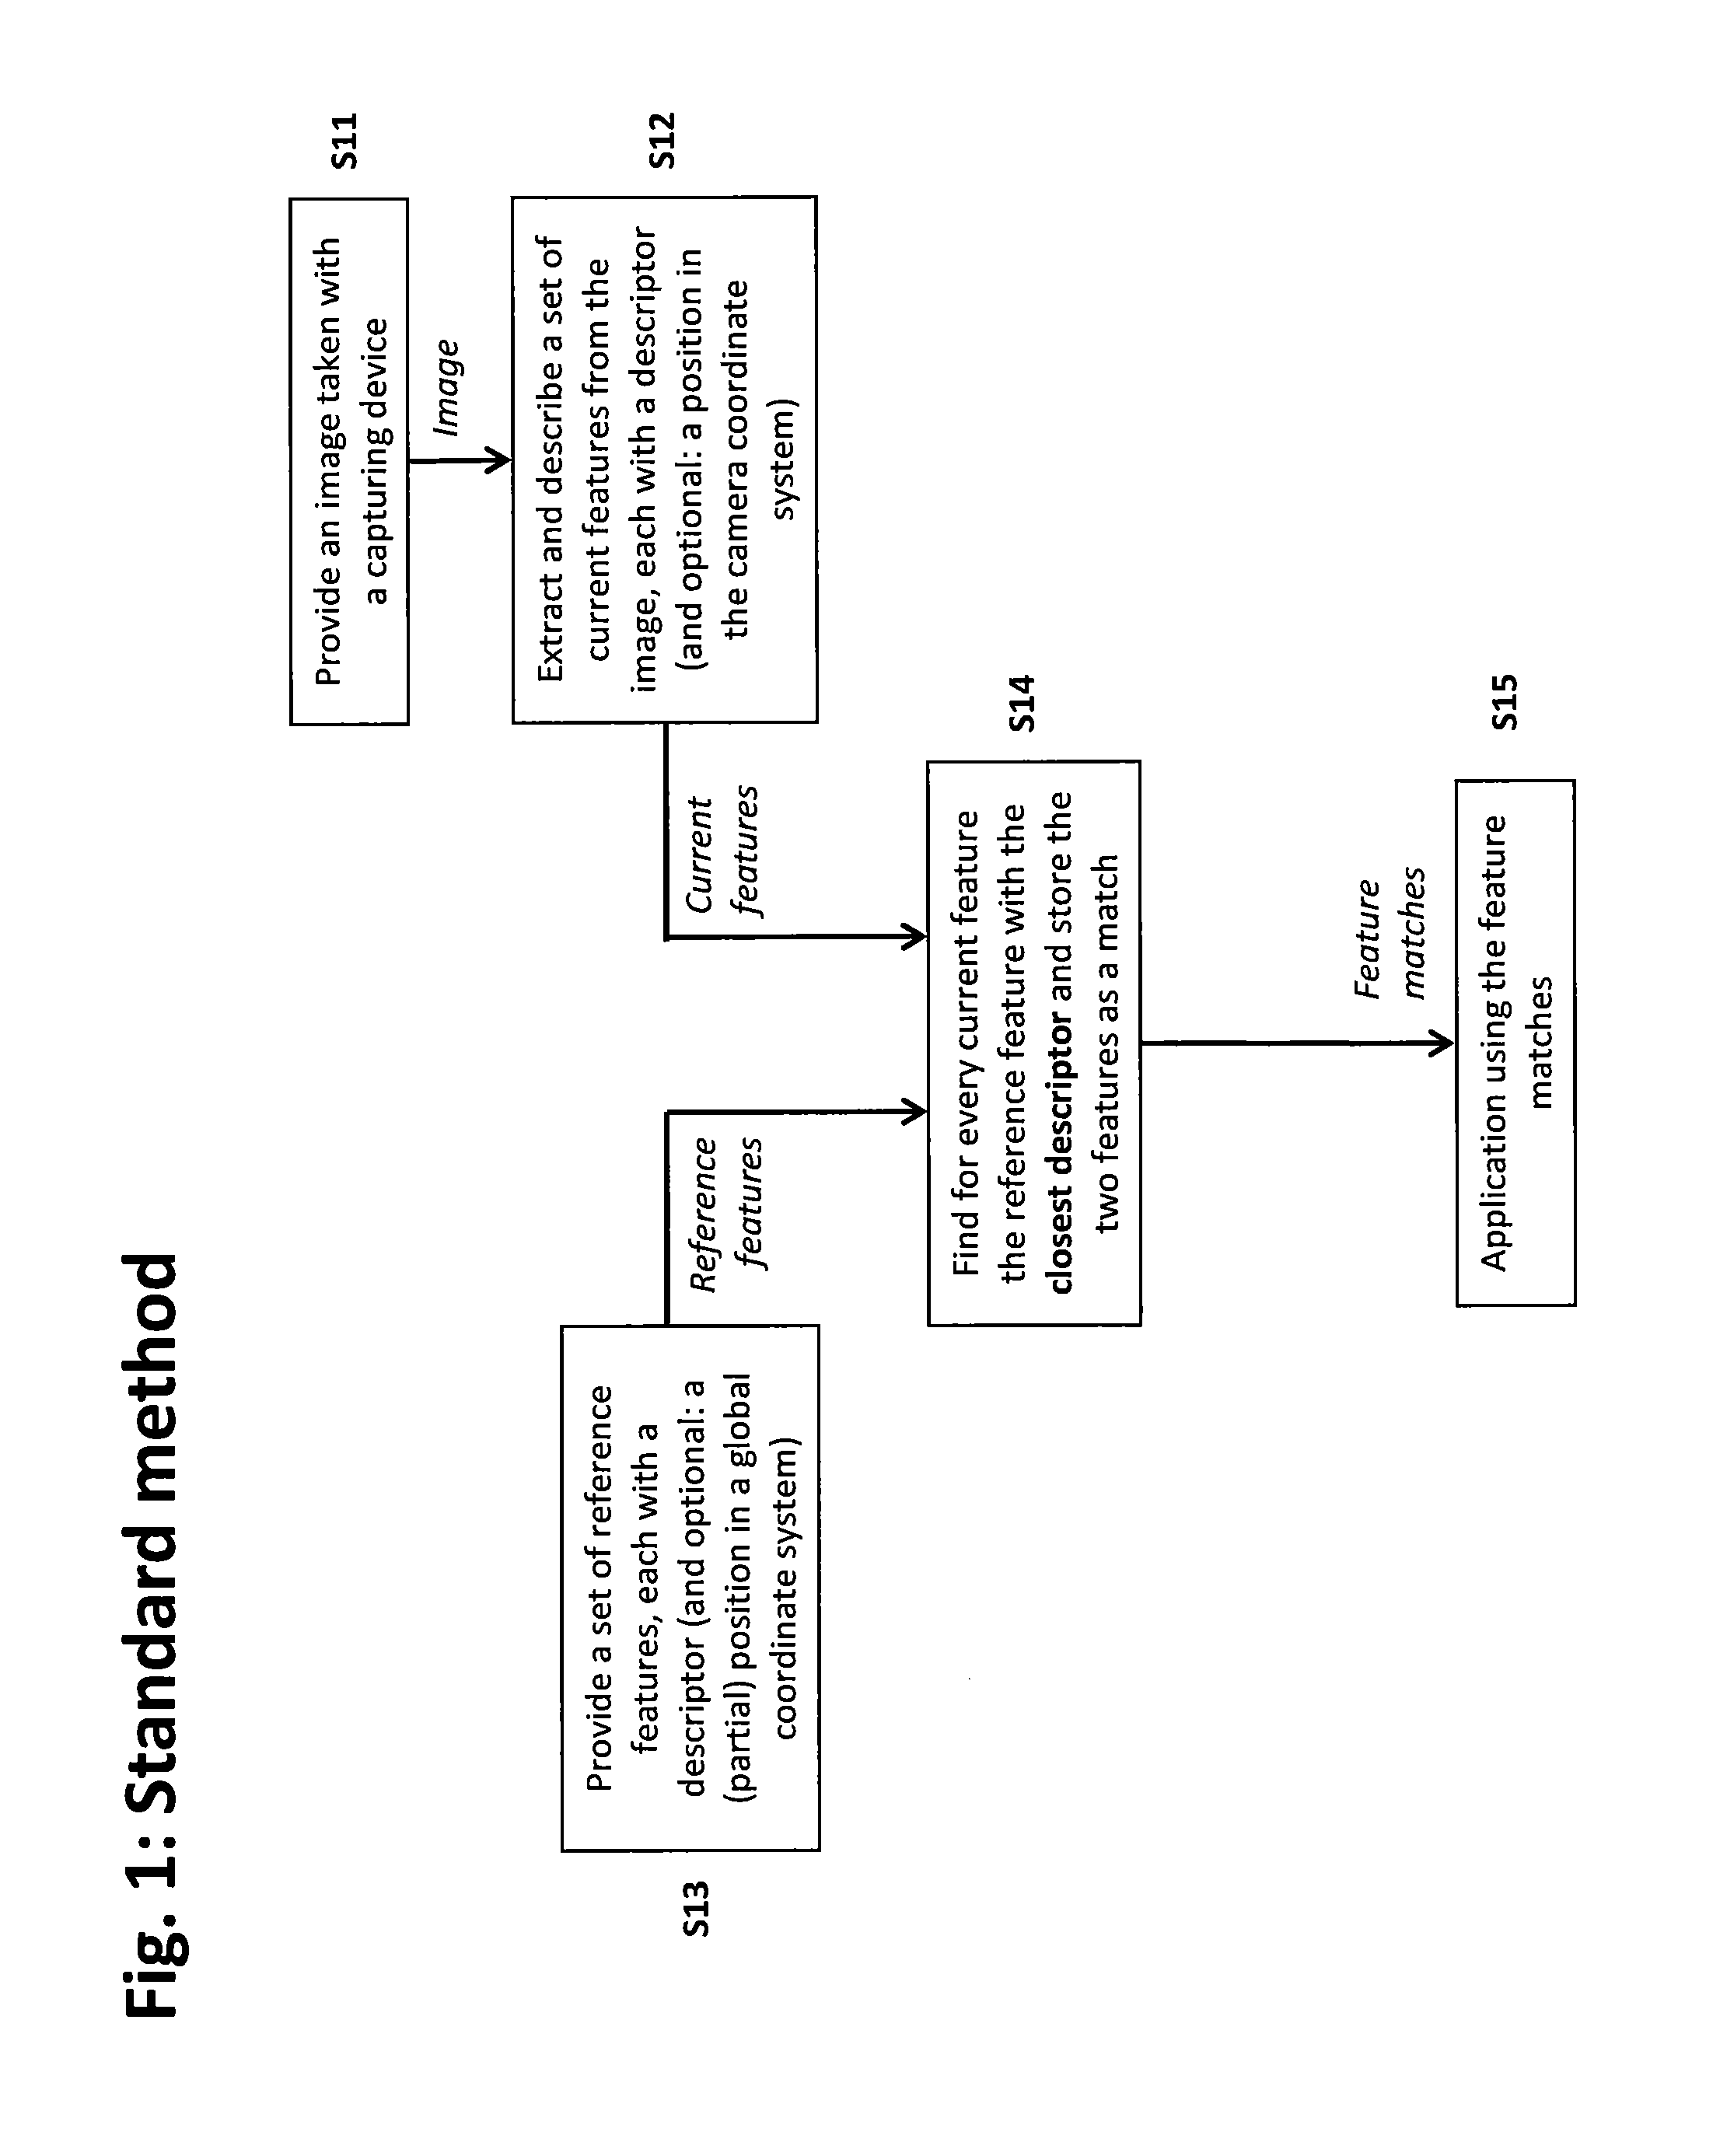
Owner:APPLE INC
Method & apparatus for an auxiliary train control system
PendingUS20150307119A1Minimize application engineering effortEasy to initializeRailway traffic control systemsVehicle route interaction devicesSelf-healingEngineering
A method and an apparatus for a train control installation are disclosed, and are based on the absolute permissive block concept. The train control installation employs a plurality of generic absolute block signal units (ABSU), wherein each signal unit includes means for detecting the crossing of a train passed a discrete point, means for exchanging data with adjacent ABSUs, means for generating and communicating a movement authority limit to a train, means for generating and displaying a signal indication, and means for enforcing a stop aspect. The train control installation can be used in conjunction with a communication based train control (CBTC) system to provide a degraded mode of operation without impacting the availability and the reliability of the CBTC system. Further, the train control installation has a self-healing feature to maintain train service during an ABSU failure.


Owner:GHALY NABIL N
Method of matching image features with reference features and integrated circuit therefor
ActiveUS9378431B2Easy to initializeImprove performanceTelevision system detailsImage analysisImaging FeatureSimilarity measure
The invention is related to a method of matching image features with reference features, comprising the steps of providing a current image captured by a capturing device, providing reference features (r), wherein each of the reference features comprises at least one reference feature descriptor (d(r)), determining current features (c) in the current image and associating with each of the current features at least one respective current feature descriptor (d(c)), and matching the current features with at least some of the reference features by determining a respective similarity measure (D(c, r)) between each respective current feature descriptor (d(c)) and each respective reference feature descriptor (d(r)). According to the invention, the determination of the similarity measure is performed on an integrated circuit by hardwired logic or configurable logic which processes logical functions for determining the similarity measure. The invention is also concerned with an integrated circuit for matching of image features with reference features.
Owner:APPLE INC
Imaging device and digital camera using the imaging device
InactiveUS6728482B2Reduce manufacturing costLow cost manufacturingTelevision system detailsPrintersCamera lensOptical power
An imaging device has a zoom lens system having a plurality of lens units and forming an optical image of an object so as to continuously optically zoom by varying distances between the lens unit; and an image sensor converting the optical image formed by the zoom lens system to an electric signal. The zoom lens system has from an object side, a first lens unit being overall negative and including a reflecting surface that bends a luminous flux substantially 90 degrees; and a second lens unit disposed with a variable air distance from the first lens unit, and having an optical power, and wherein at least one lens element made of resin is included in the entire lens system.
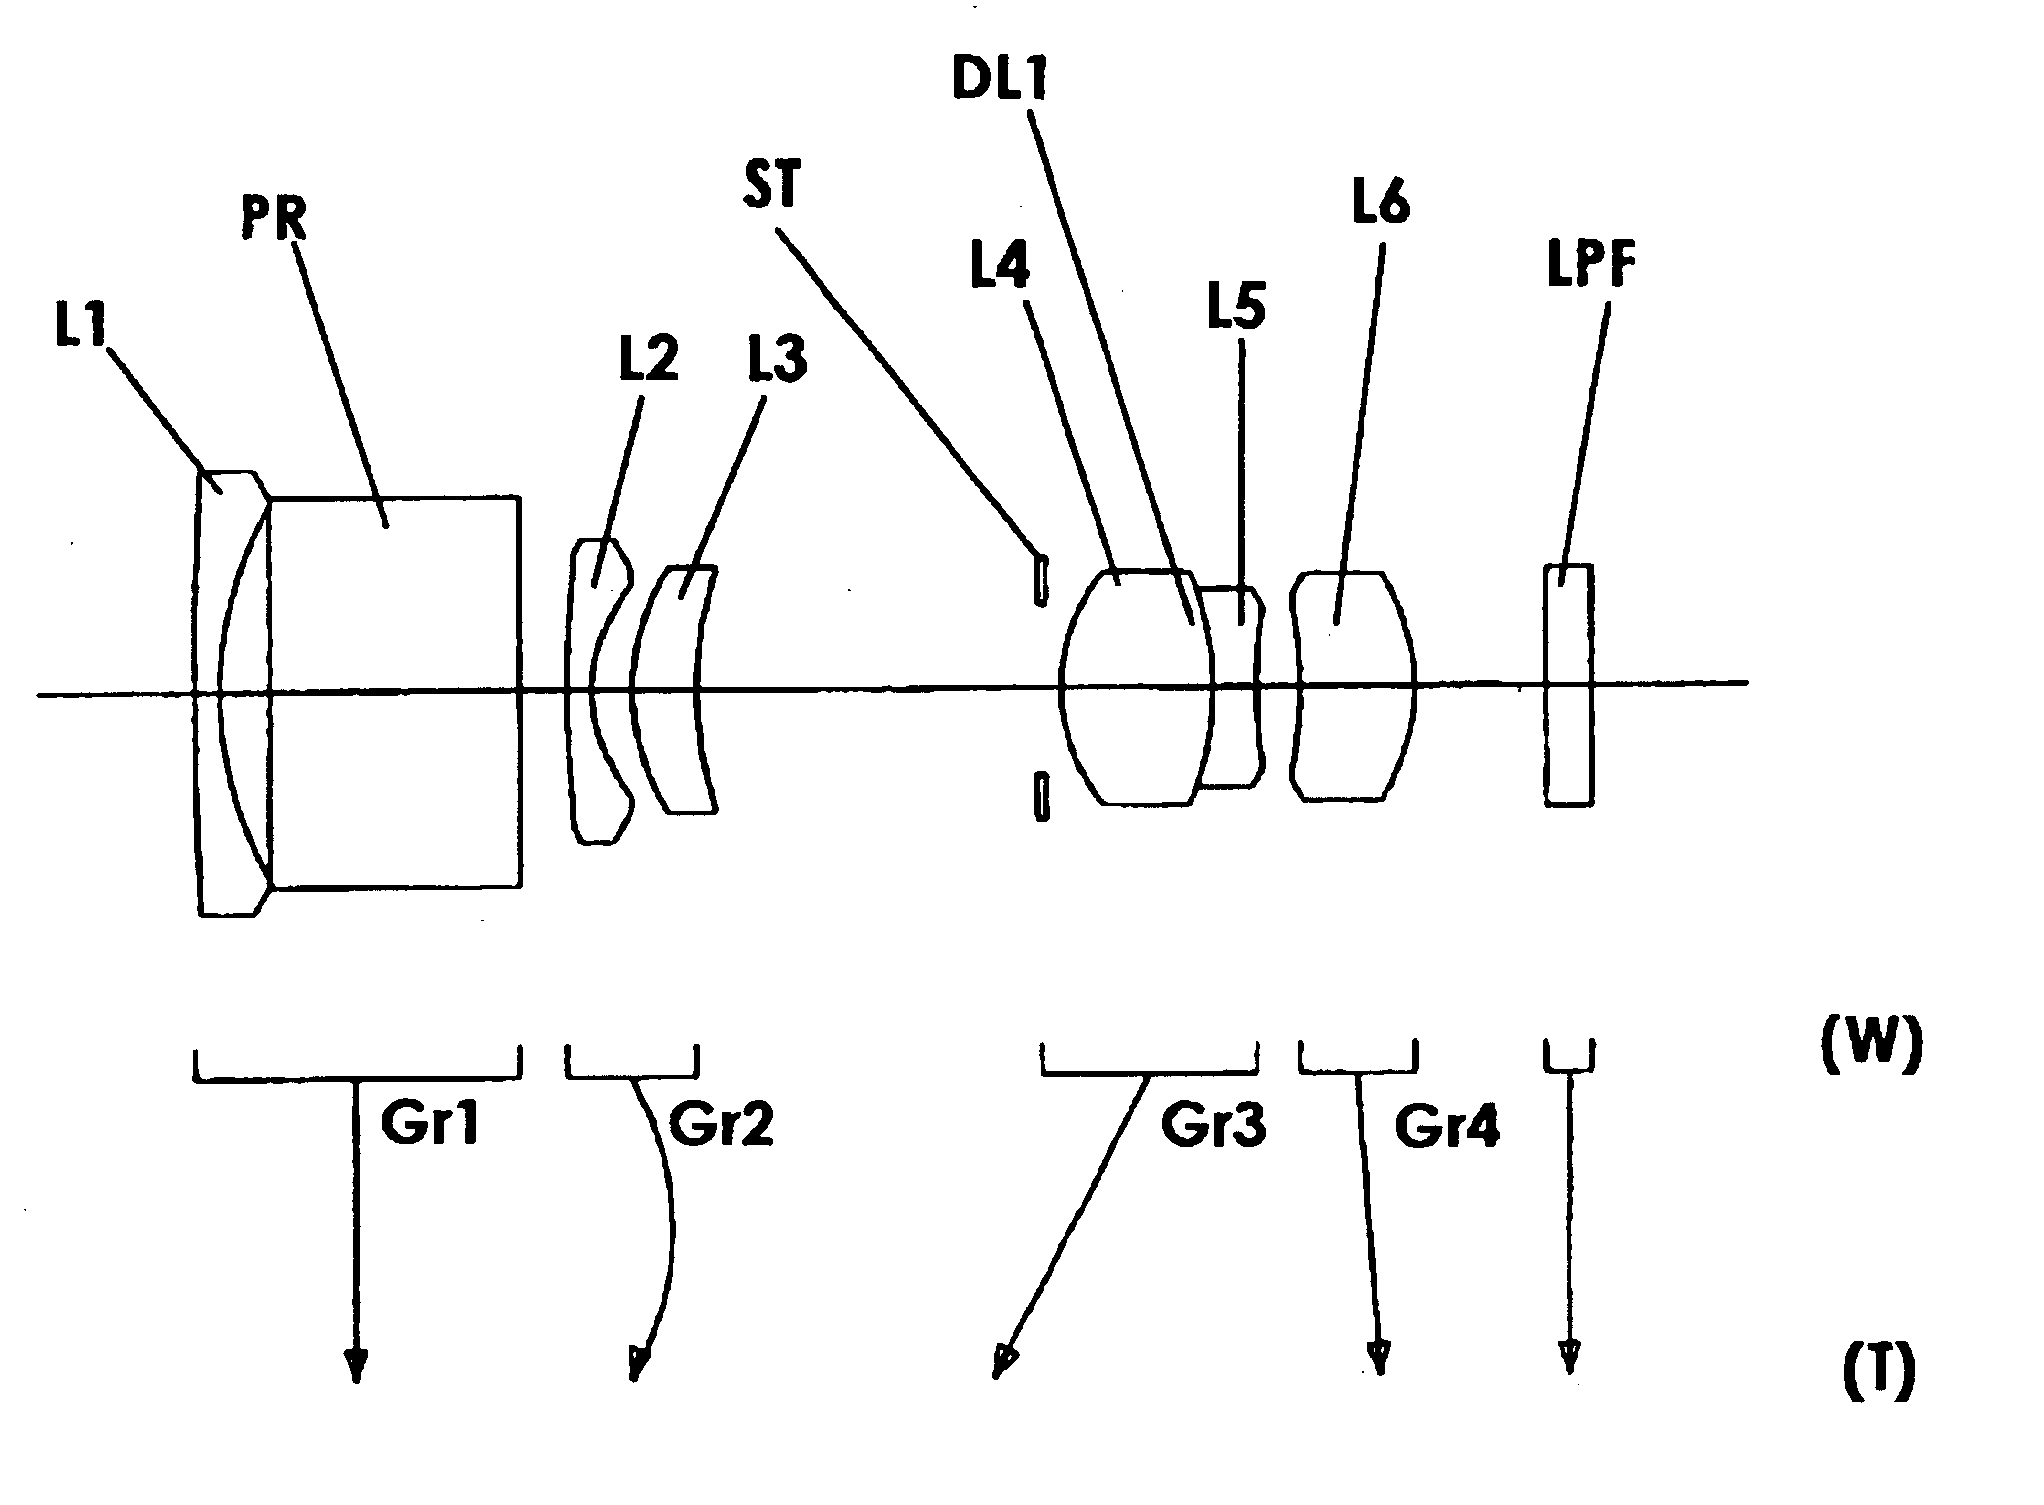
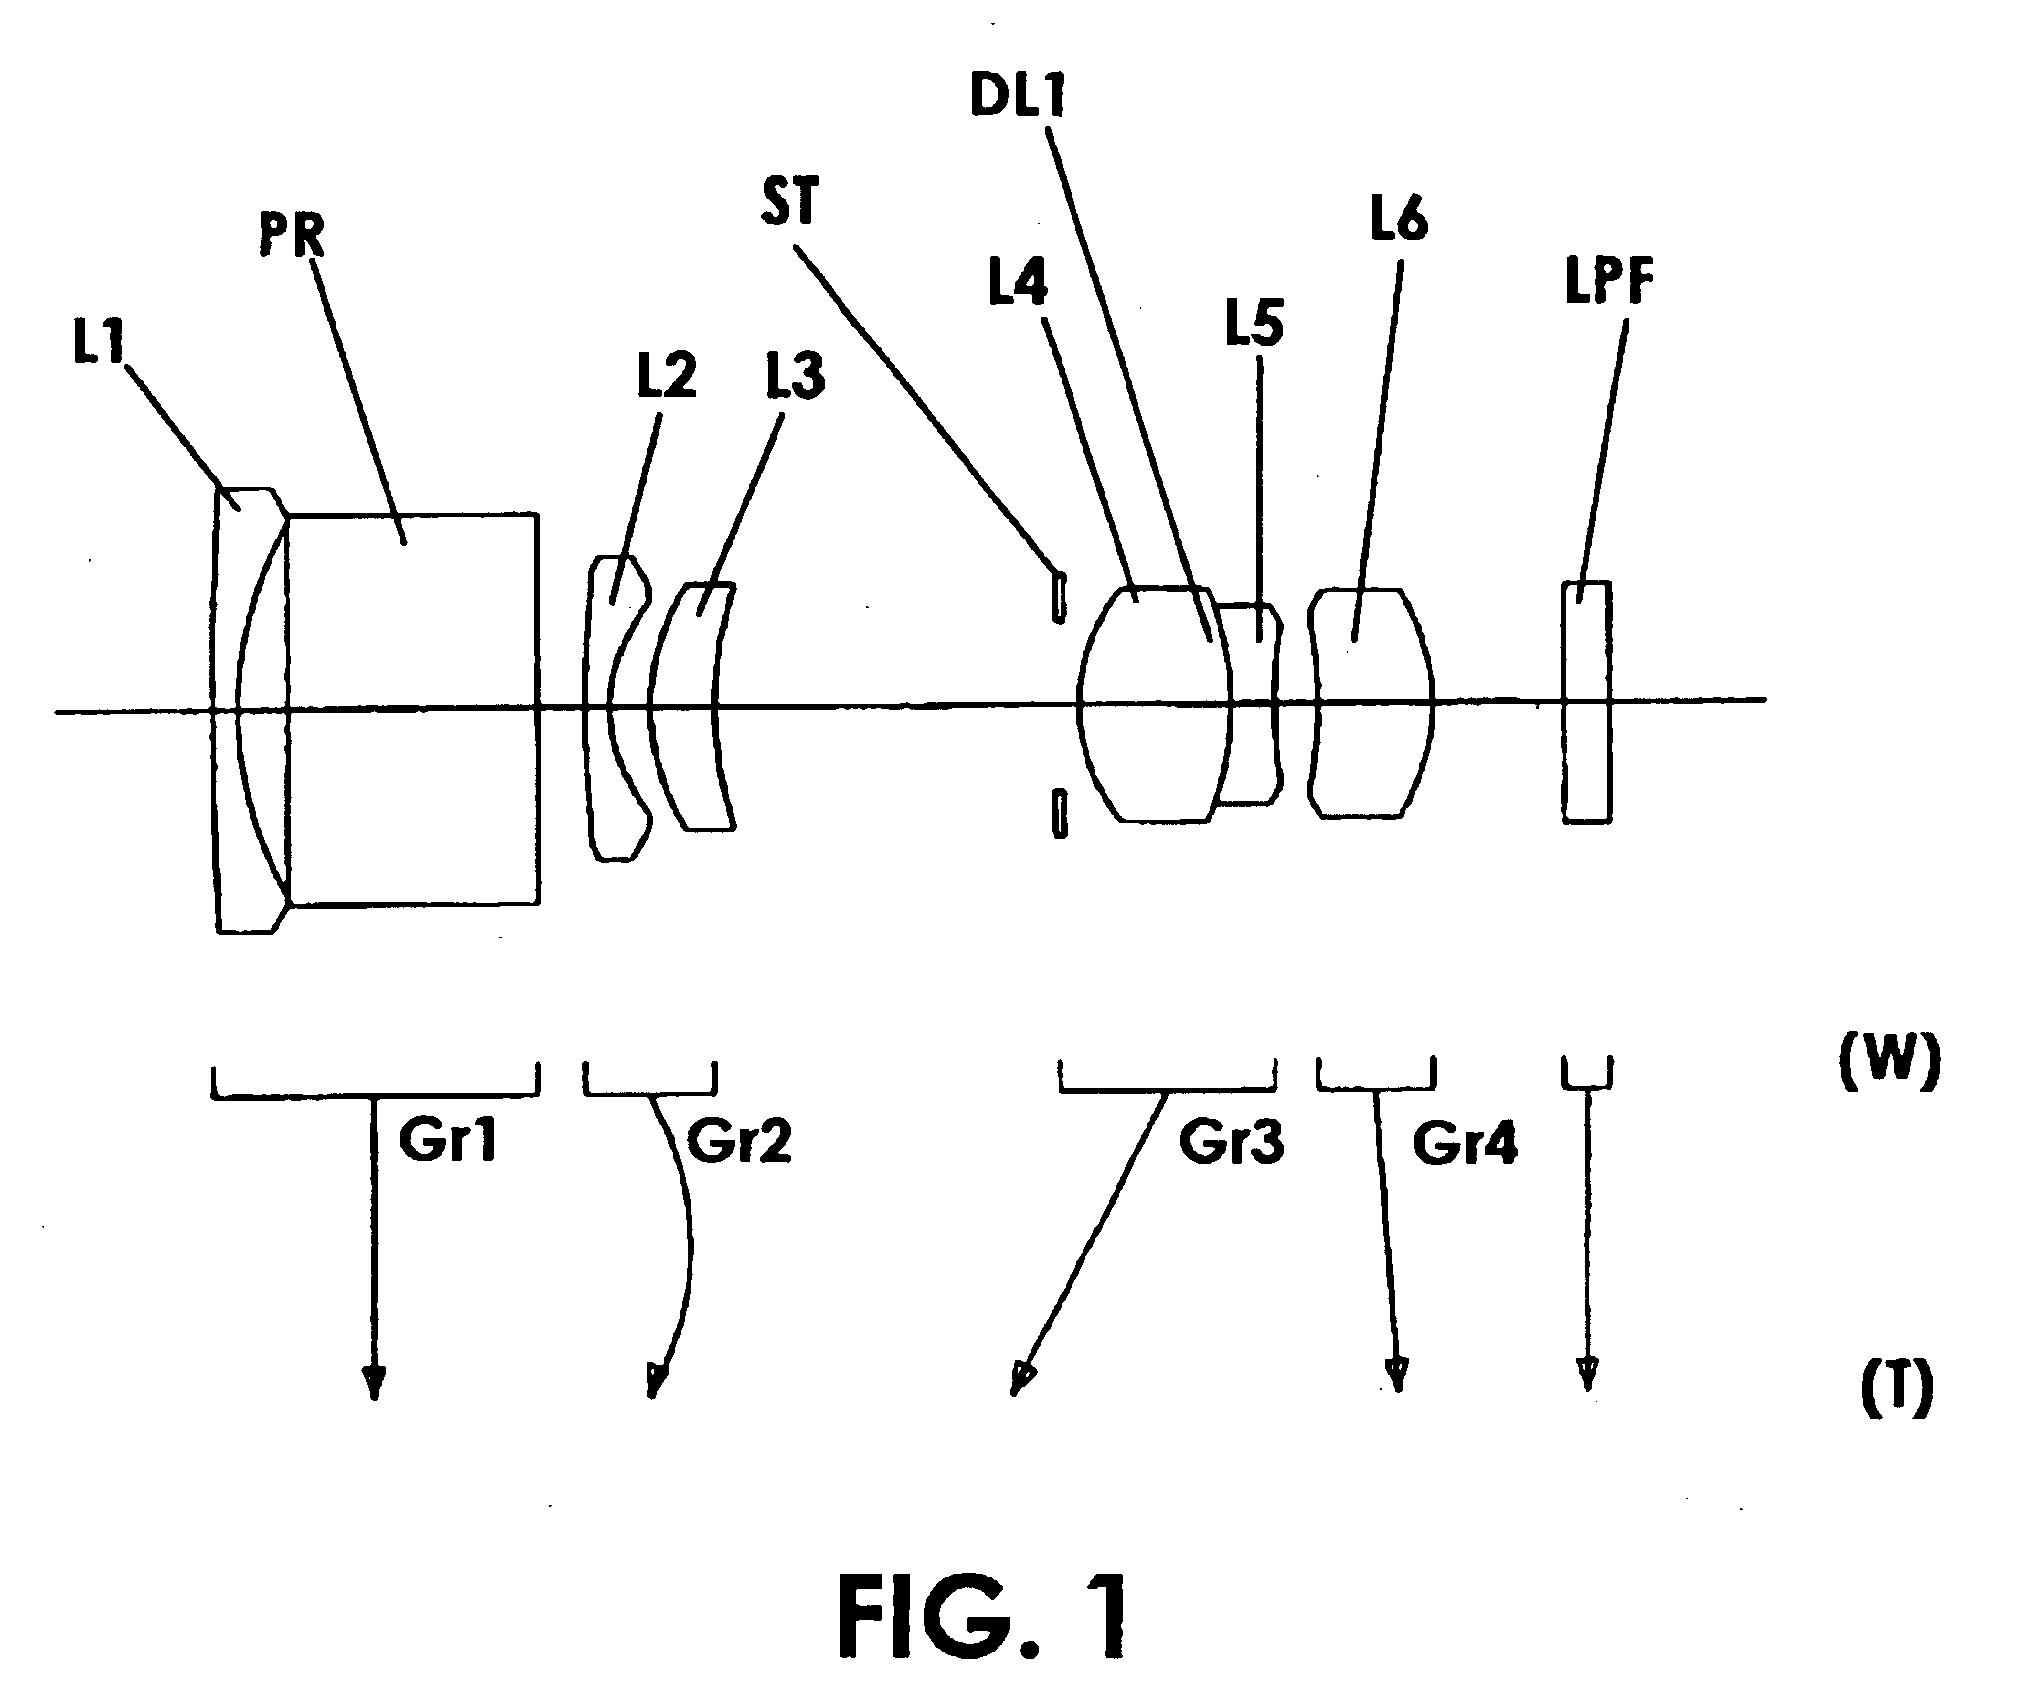
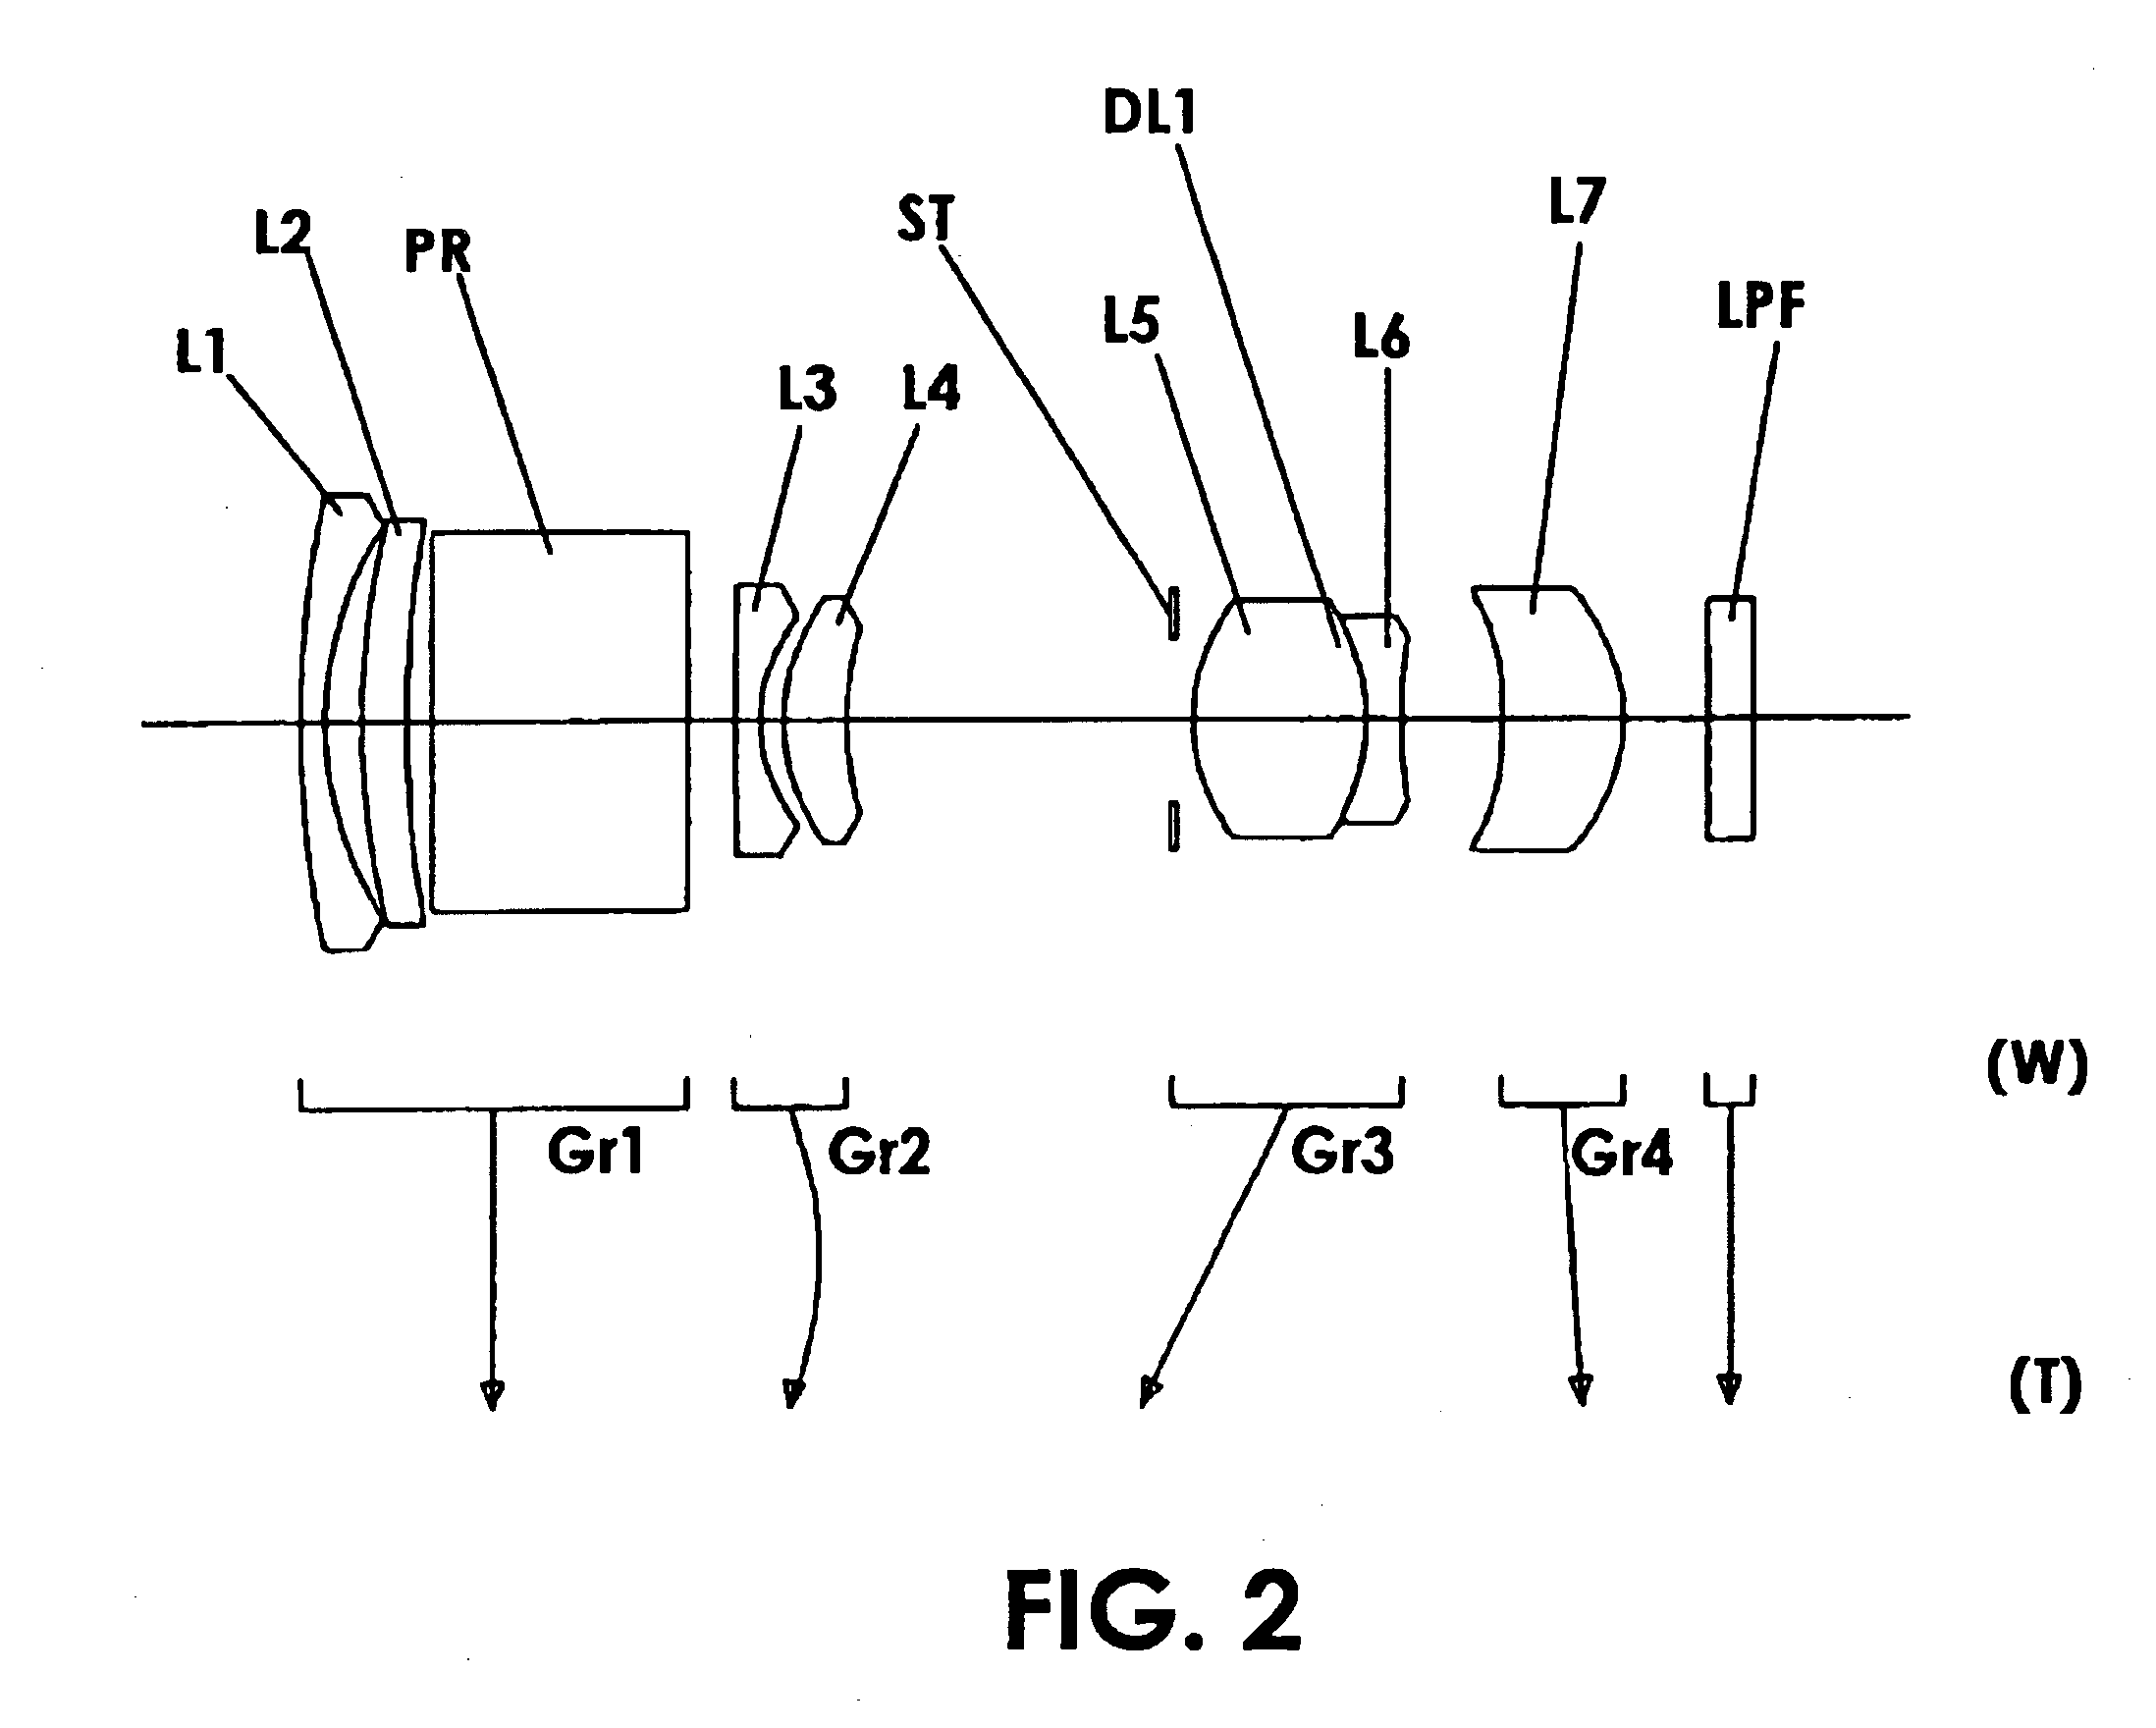
Owner:MINOLTA CO LTD
Task scheduling method based on depth reinforcement learning under vehicle network environment
ActiveCN107145387AStrong fault toleranceEasy to initializeProgram initiation/switchingResource allocationNerve networkReinforcement learning
The invention discloses a task scheduling method based on depth reinforcement learning under a vehicle network environment; the method comprises the following steps: 1, obtaining vehicle flowrate data in the coverage scope of each road side unit; 2, obtaining load data of each road side unit, and transferring the data to other road side units in a multicast mode; 3, building a depth nerve network, and initializing related variables; 4, randomly selecting local execution or loading to other road side unit for execution of a request arriving in a scope in the initial time, and recording the time duration of the request from arrival to finish; 5, updating the nerve network when the data collected in step 4 reaches certain level; 6, receiving newly arrived requests, and using the updated nerve network to distribute according to the vehicle flowrate in each area and the load of each road side unit; 7, collecting data, and repeating steps 5-6.
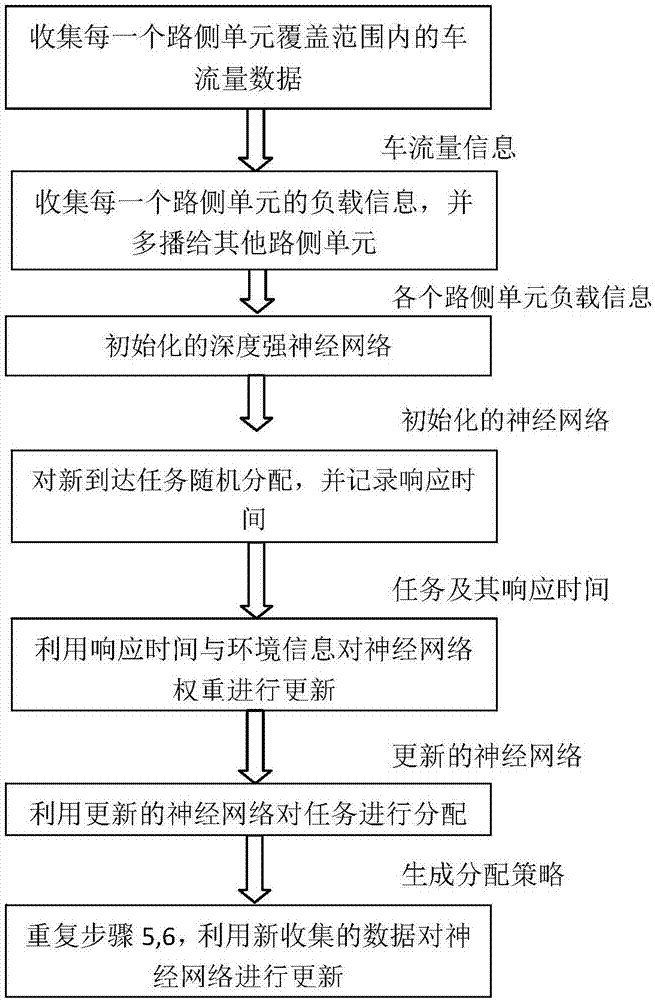
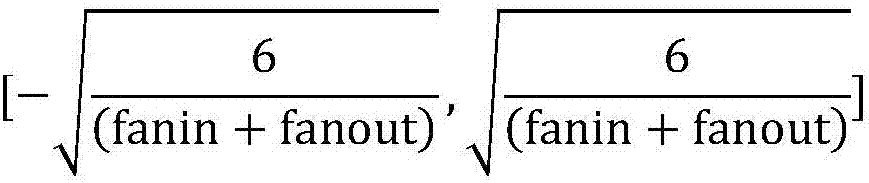
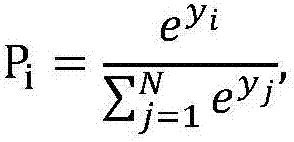
Owner:NANJING UNIV
Collaborative synchronous positioning and map building method and system and interactive system
ActiveCN107818592ACollaborative workEasy to initializeNavigation instrumentsTransmissionKey frameCooperative work
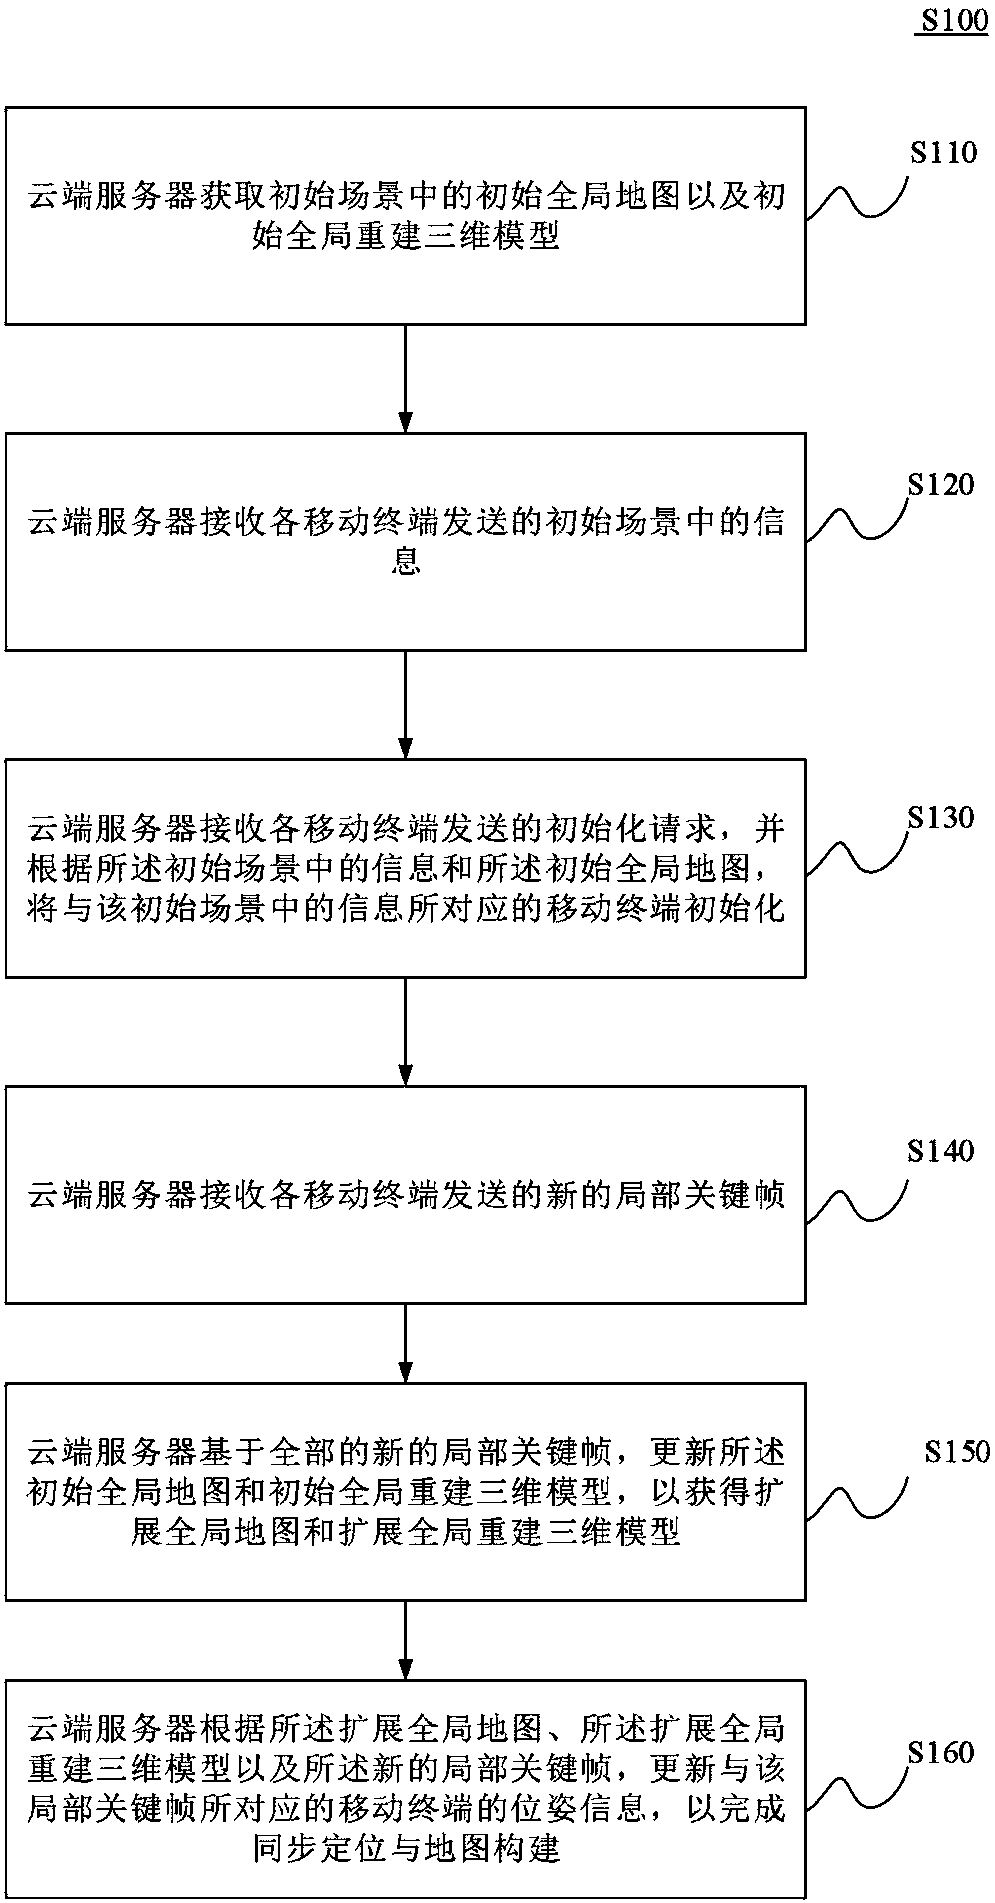
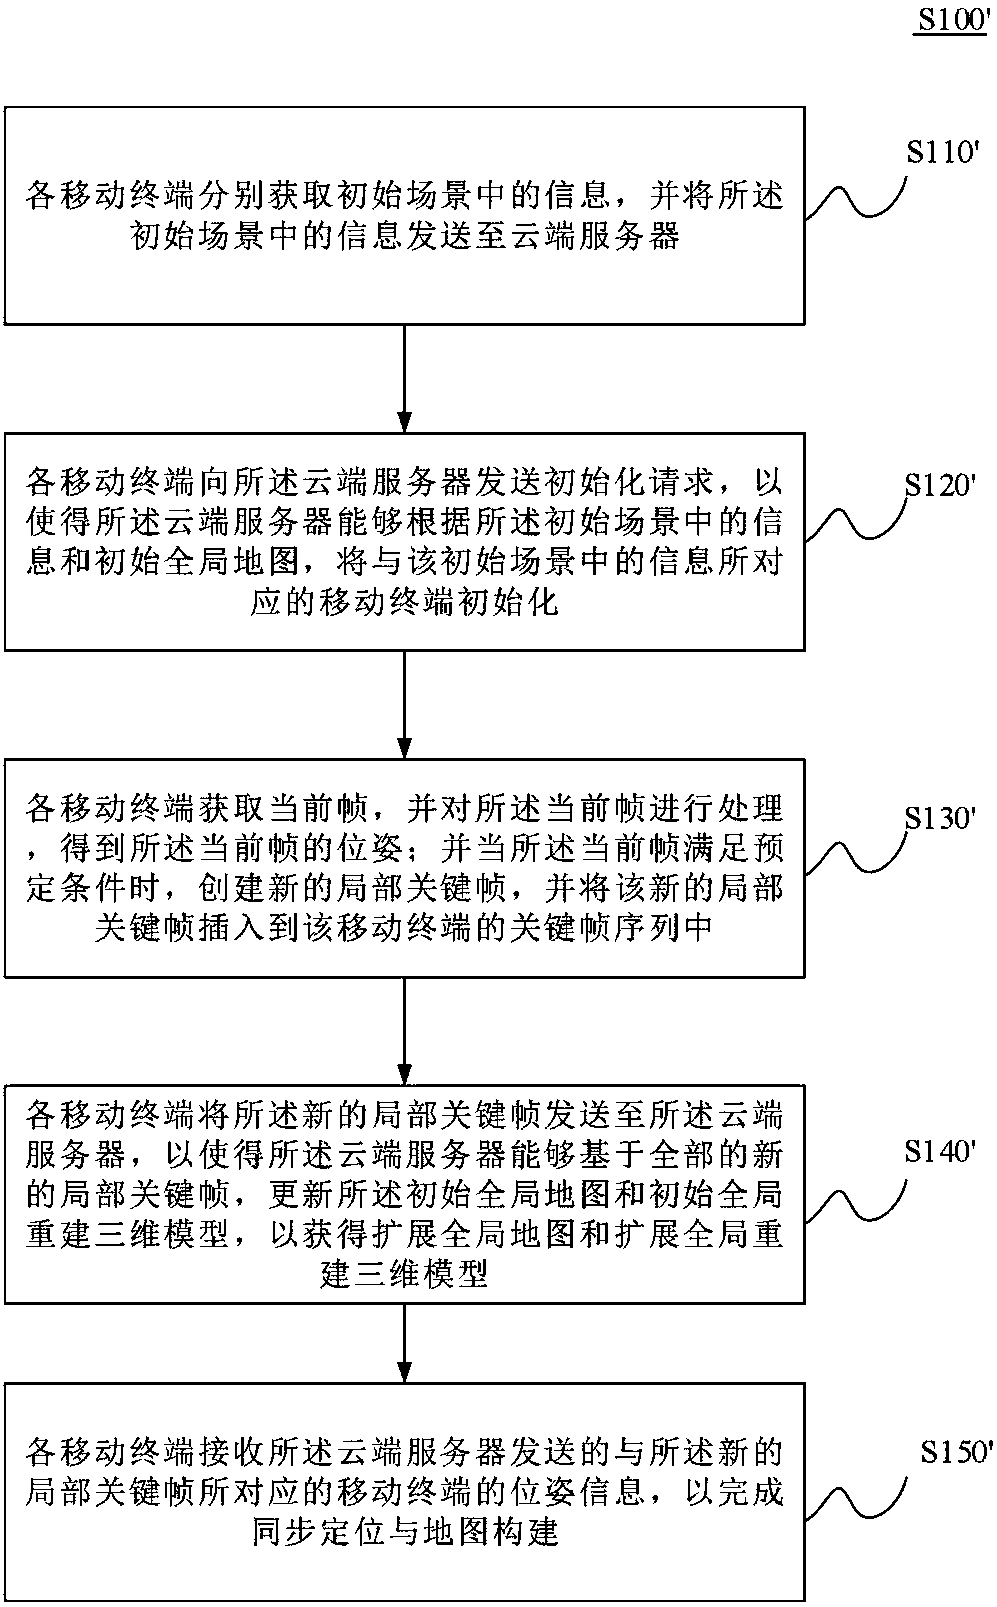
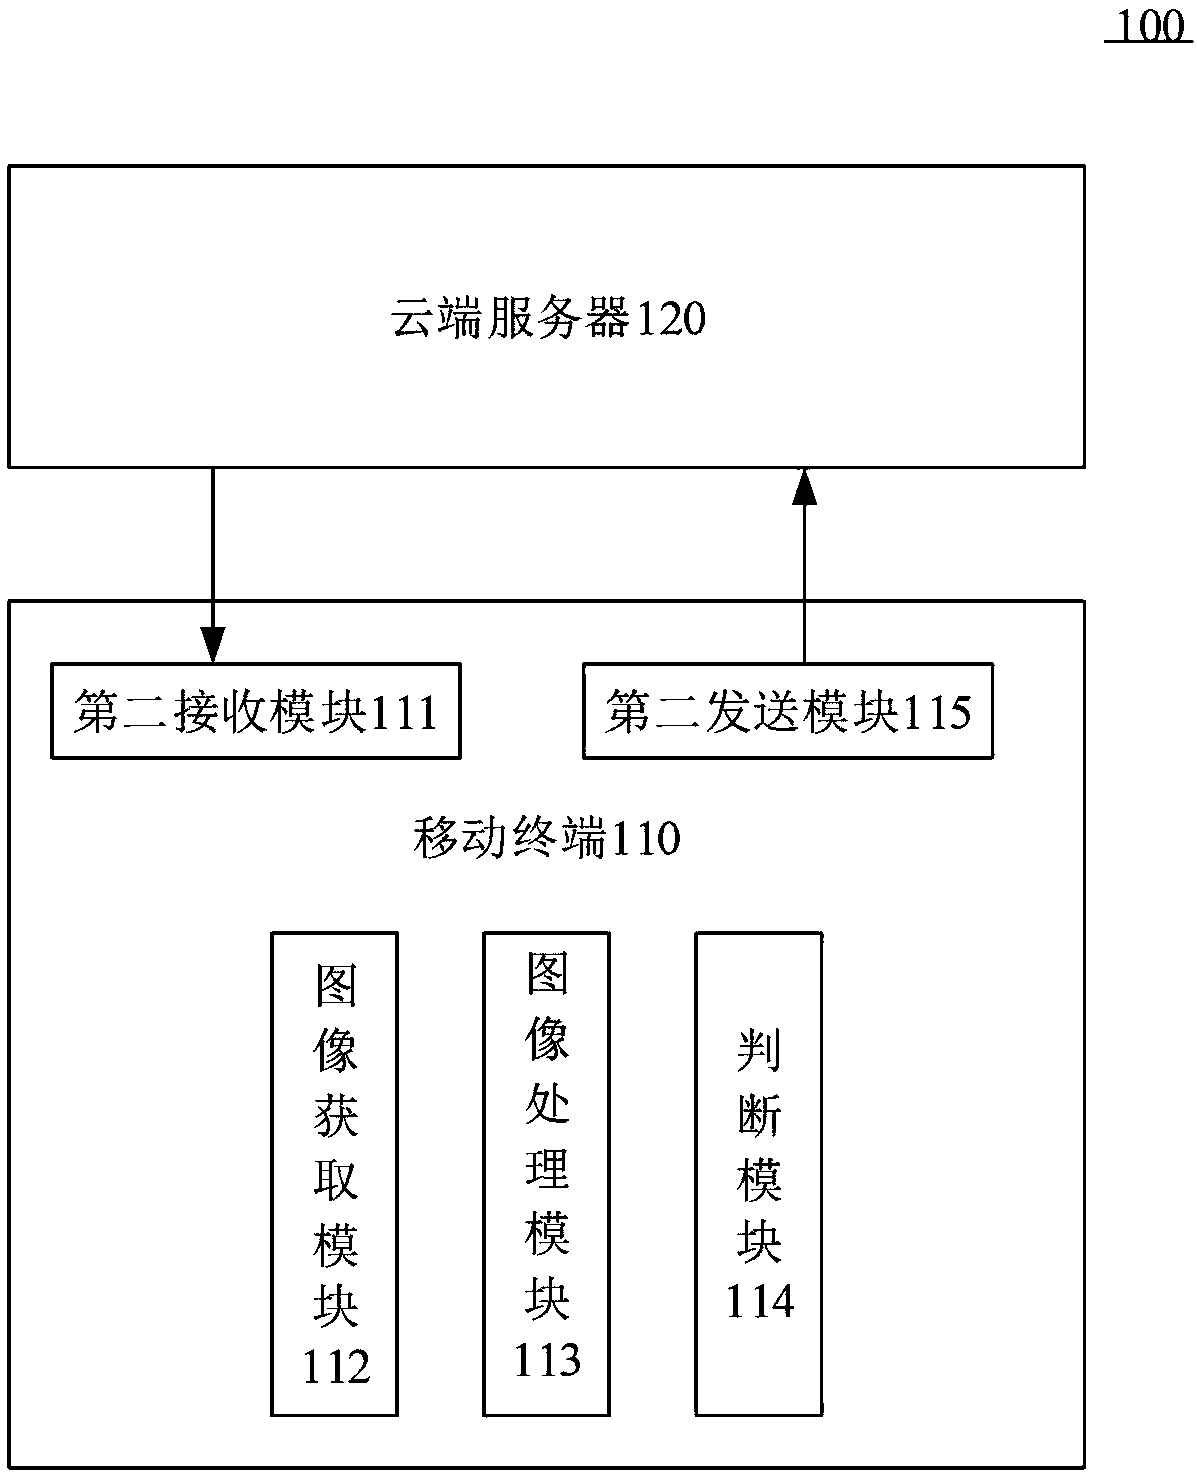
The invention discloses a collaborative synchronous positioning and map building method and system and an interactive system. The method comprises the steps: enabling a cloud server to obtain an initial global map in an initial scene and an initial global constructed three-dimensional model; receiving the information and initialization requests, sent by all mobile terminals, in the initial scene,and initializing the mobile terminal corresponding to the information in the initial scene according to the information and initial global map in the initial scene; receiving a new local key frame sent by each mobile terminal, updating the initial global map and the initial global constructed three-dimensional model, so as to obtain an extended global map and an extended global constructed three-dimensional model; updating the posture information of the mobile terminal corresponding to the local key frame according to the extended global map, the extended global constructed three-dimensional model and the new local key frame, so as to complete the synchronous positioning and map reconstruction. The method can achieve the cooperative work of all mobile terminals, and is very high in real-time performance, stability and robustness of a system.
Owner:BEIJING HUAJIE IMI TECH CO LTD
Initialization method and system of monocular SLAM algorithm
ActiveCN110060202AImprove stabilityImprove calculation accuracyImage analysisGeometric image transformationMonocular slamBinocular distance
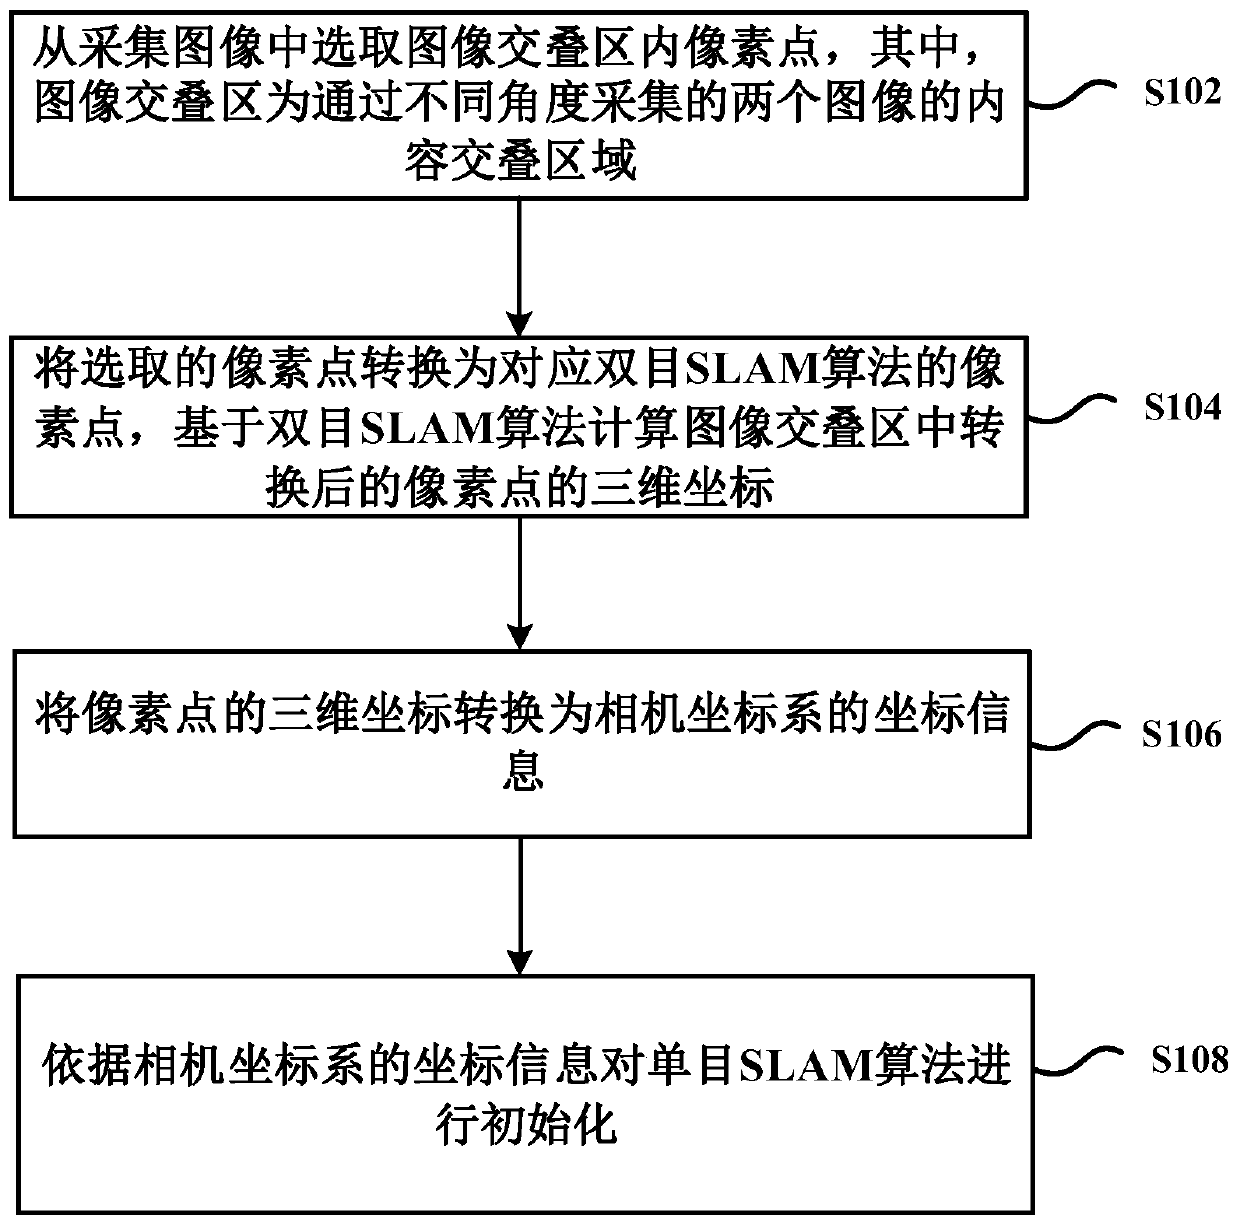
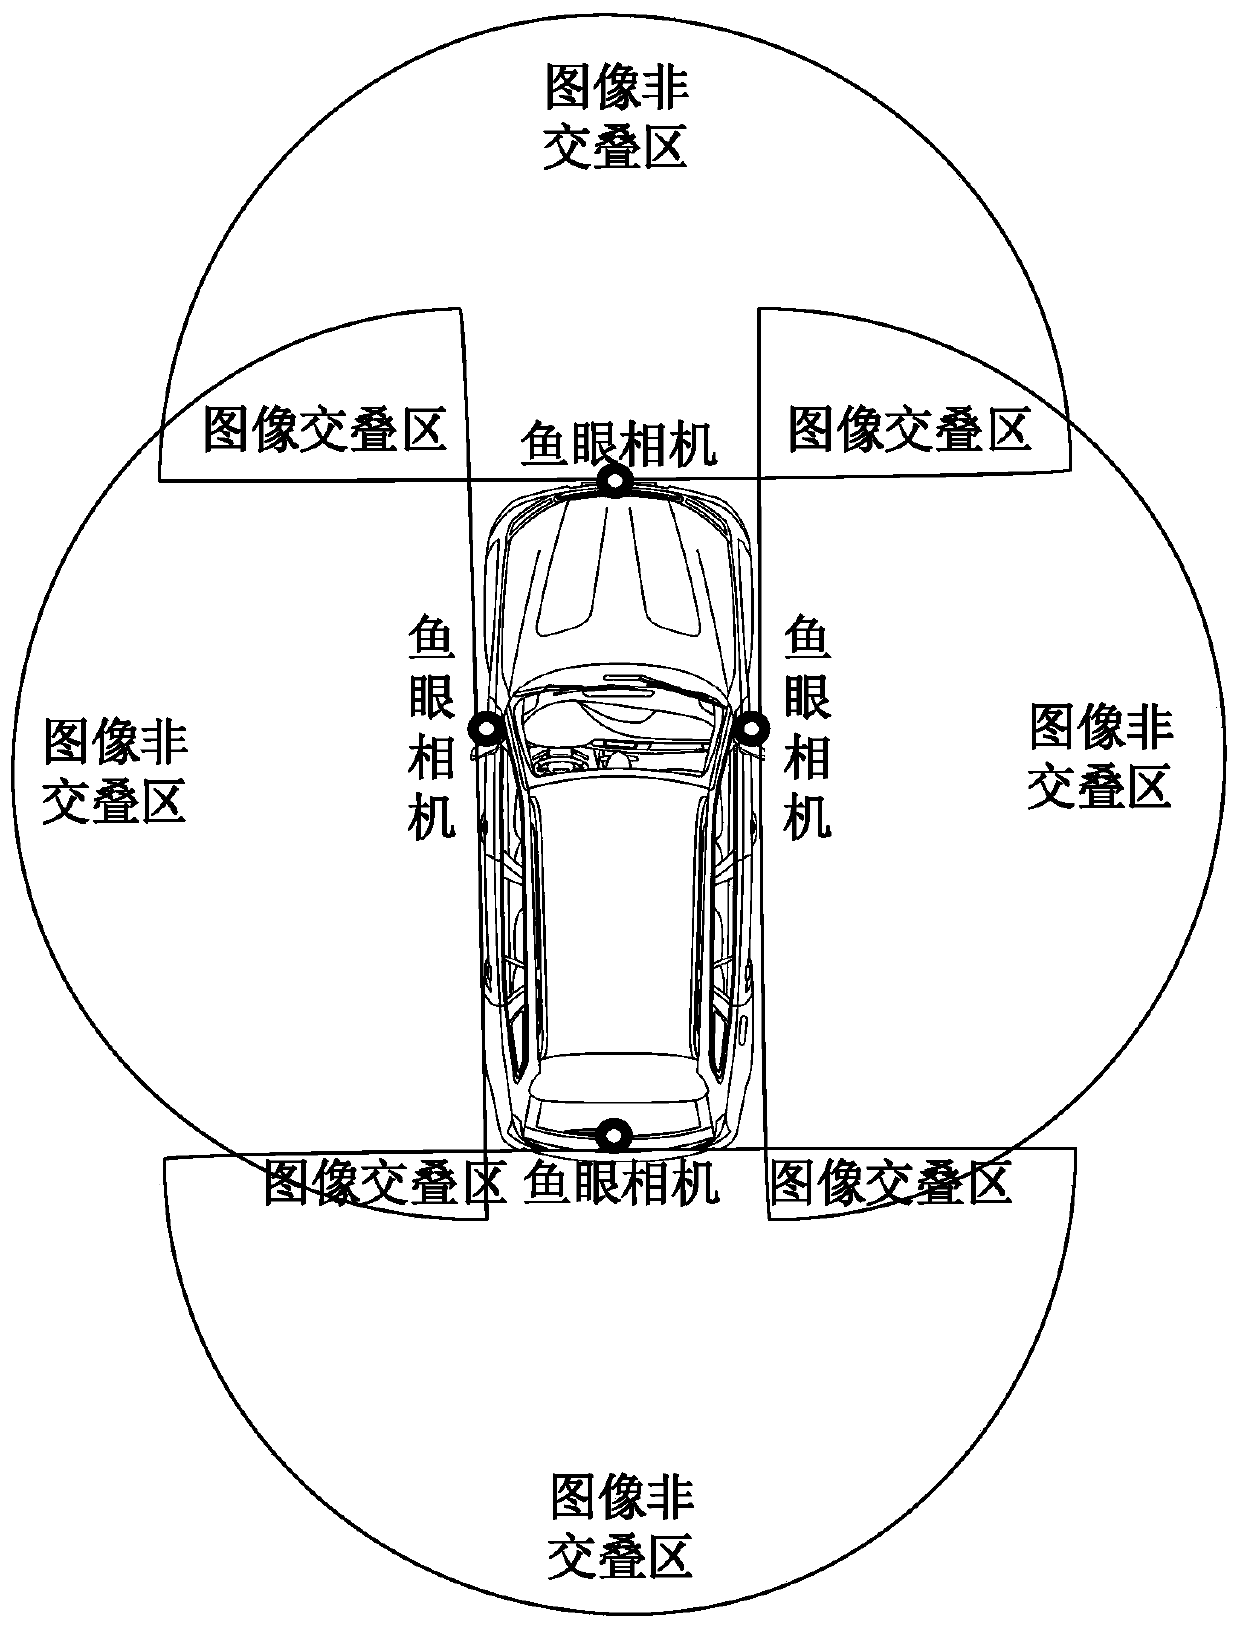
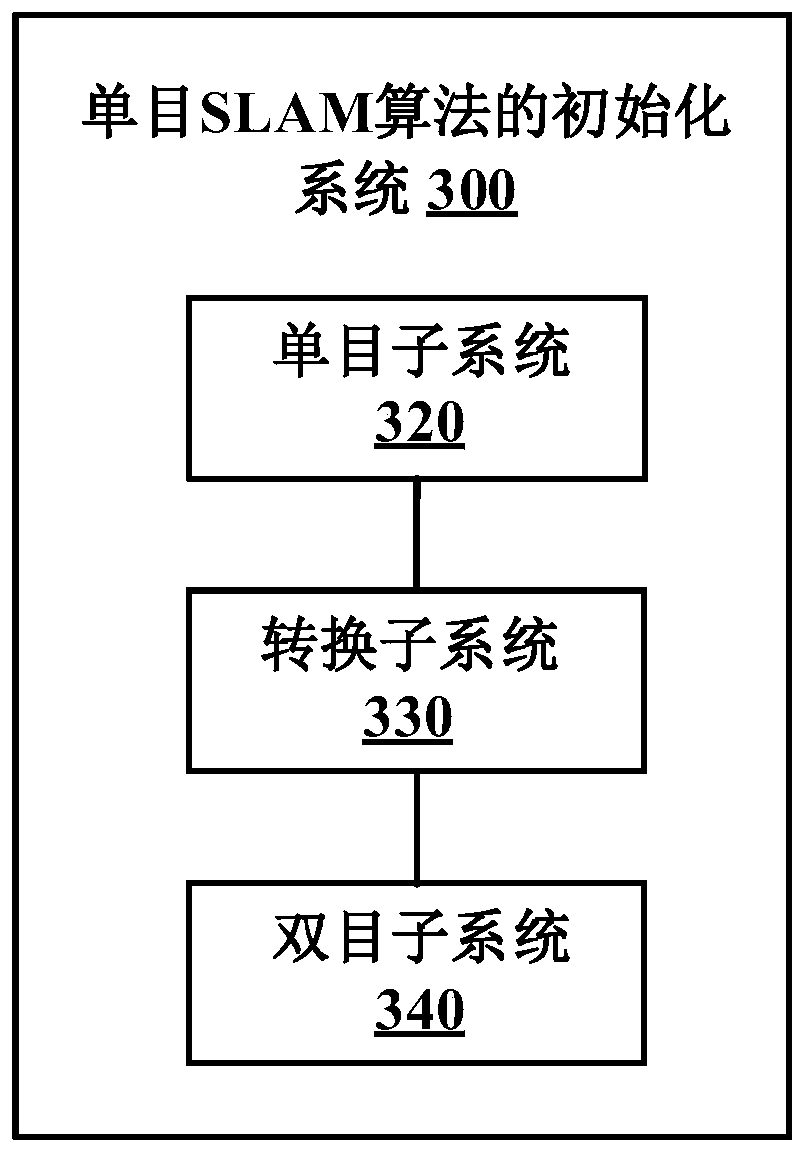
The invention provides an initialization method and system of a monocular SLAM algorithm. The method comprises the following steps of selecting pixel points in the image overlapping area from the acquired image; converting the selected pixel points into pixel points corresponding to the binocular SLAM algorithm; and calculating the three-dimensional coordinates of the converted pixel points in theimage overlapping area based on a binocular SLAM algorithm, converting the three-dimensional coordinates of the pixel points into coordinate information of a camera coordinate system, and initializing the monocular SLAM algorithm according to the coordinate information of the camera coordinate system. Therefore, according to the embodiment of the invention, the monocular SLAM algorithm can be assisted to realize initialization according to the binocular SLAM algorithm, so that the monocular system corresponding to the monocular SLAM algorithm can realize initialization faster and better, andthe stability and the calculation precision of the monocular SLAM algorithm are improved.
Owner:ECARX (HUBEI) TECHCO LTD
Cell tracing method based on deep neural network
InactiveCN106204642AImprove feature extractionEasy to initializeImage enhancementImage analysisPositive sampleImaging processing
The invention discloses a cell tracing method based on a deep neural network, relates to the technical field of image processing, and solves the problem of tracing a cell in a continuous microscope cell picture sequence. The method comprises the steps of collecting cell picture data, cutting out cell data, extracting characteristics of the cell by using a convolutional neural network, and acquiring an initialized multitask observation model; giving a first picture and a cell position of the microscope picture sequence, acquiring a candidate cell position close to the cell position in the first picture from the next frame of picture; sampling a positive sample and a negative sample on the first picture, training the initialized multitask observation model, and predicting the candidate cell position, thus obtaining a predicted similarity probability value of the cell; and predicting the candidate cell position with the largest similarity probability value to be the cell position of the next frame of picture, storing the largest predicted similarity probability value and the corresponding cell position in a model update strategy, and comparing with a threshold value. The cell tracing method provided by the invention is used for tracing the cell.


Owner:SICHUAN UNIV
Scan region determining apparatus
ActiveUS20150139520A1Robust determinationReduce probabilityImage enhancementImage analysisComputer visionComputer science
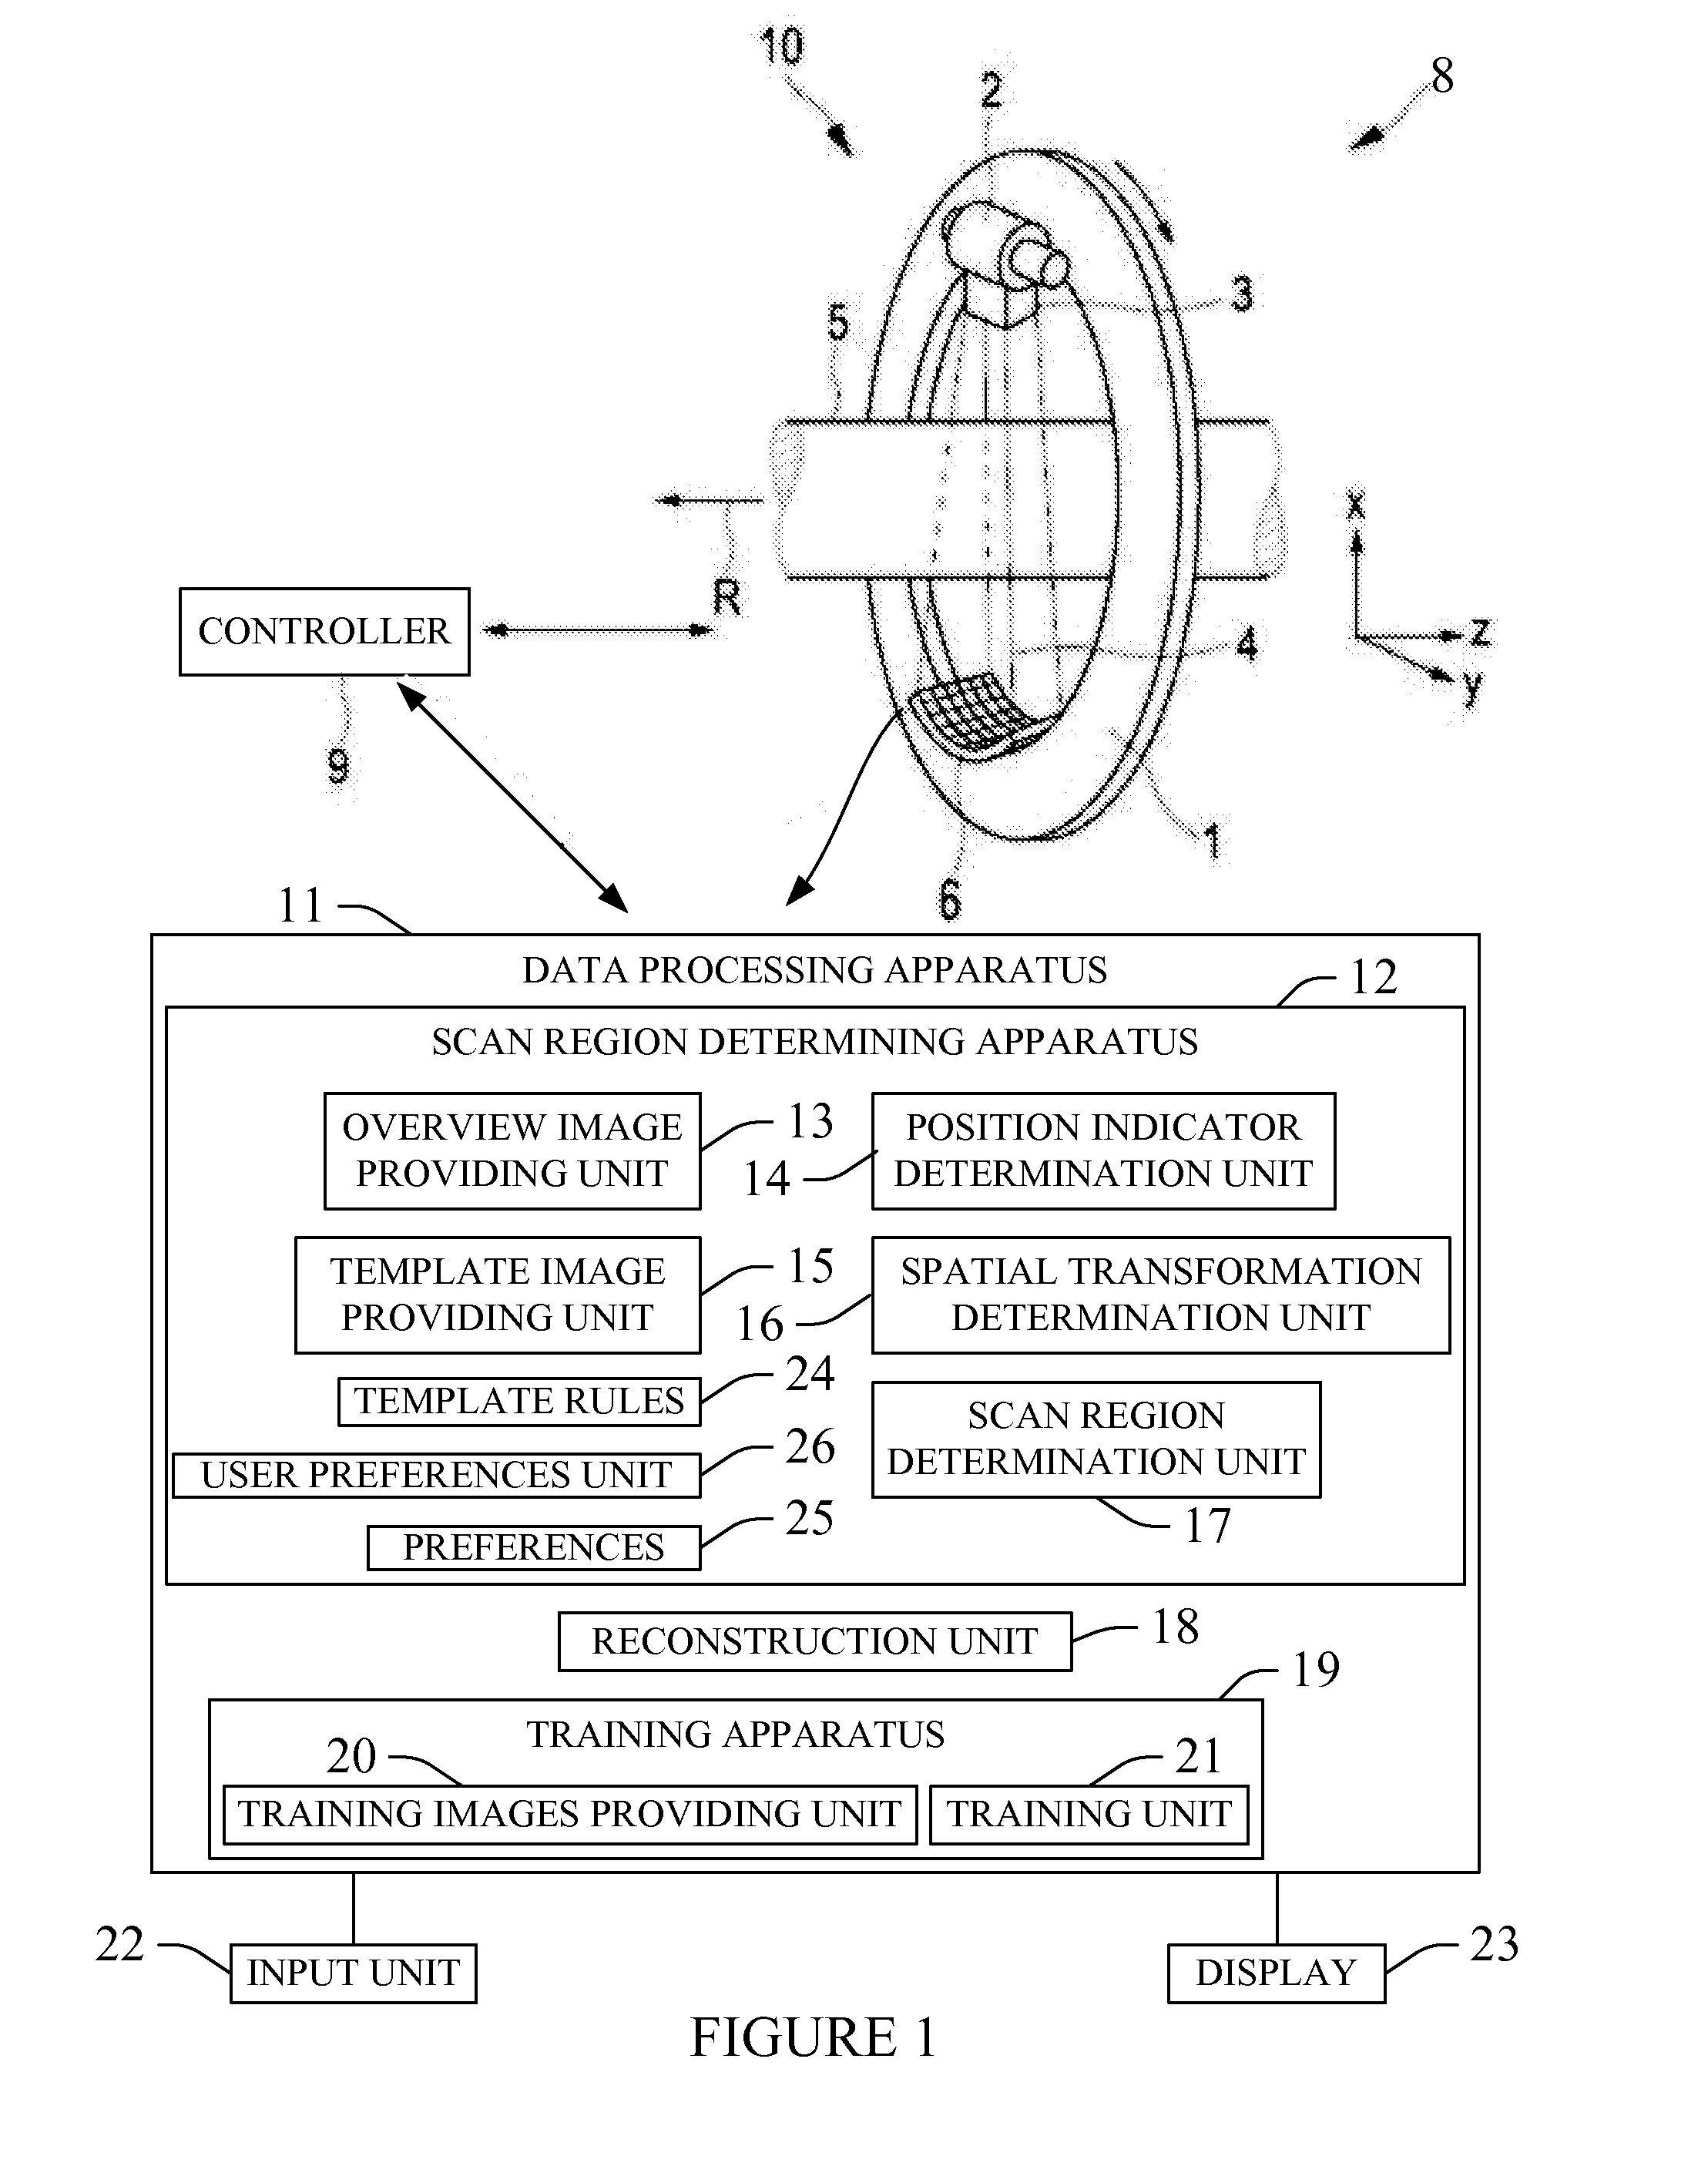
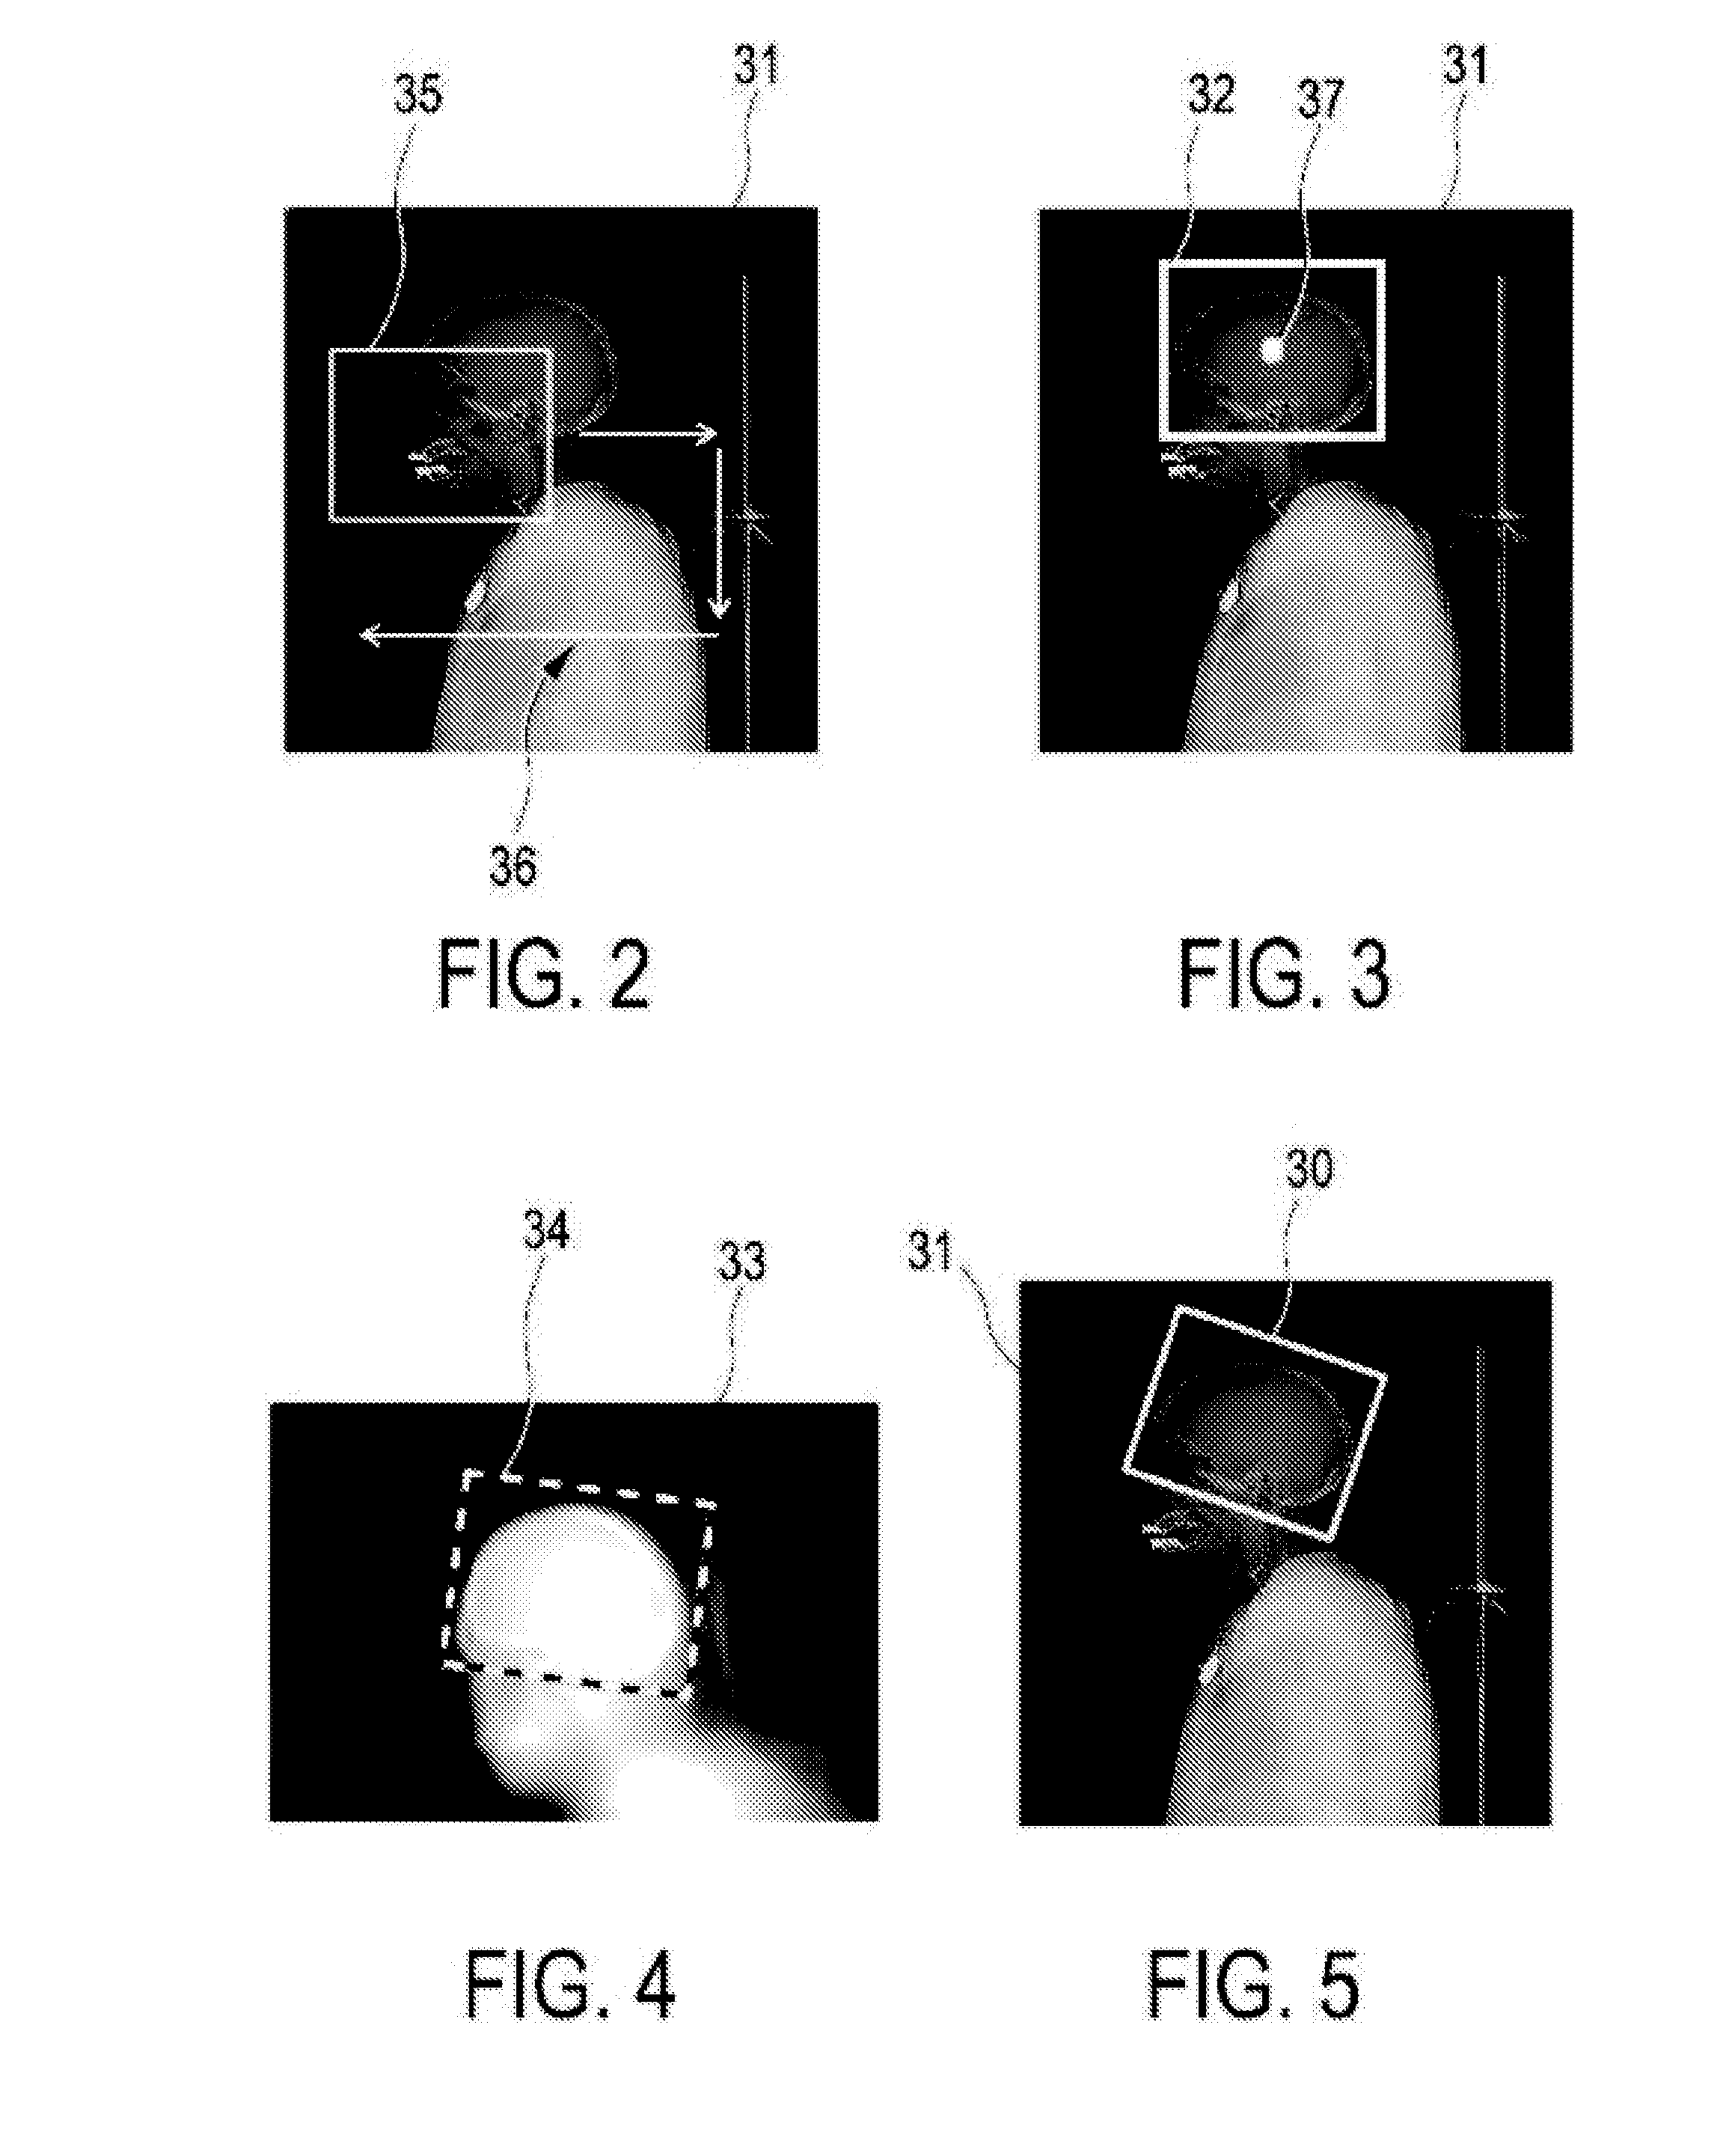
A method includes displaying an iconic image of the human body and a list of predetermined anatomical regions. The method further includes displaying, in response to a user selected anatomical region, a scan box over a sub-portion of the iconic image. The method further includes receiving an input indicative of at least one of a scan box location of interest or a scan box geometry of interest, with respect to the anatomical region, of the first user. The method further includes at least one of re-locating or changing a geometry of the first initial scan box, in response thereto, creating a first user defined scan box for the first user. The method further includes creating a first transformation between a first template image representative of the selected anatomical region and the iconic image with the first user defined scan box for the first user, and storing the first transformation.
Owner:KONINKLJIJKE PHILIPS NV
Apparatus and method for processing an audio signal to obtain a processed audio signal using a target time-domain envelope
ActiveUS20170345433A1Quality improvementReduce the number of iterationsSpeech synthesisTime domainFrequency spectrum
Subject of the invention is an apparatus described by a schematic block diagram for processing an audio signal to obtain a processed audio signal. The apparatus includes a phase calculator for calculating phase values for spectral values of a sequence of frequency-domain frames representing overlapping frames of the audio signal. Moreover, the phase calculator is configured to calculate the phase values based on information on a target time-domain envelope related to the processed audio signal, so that the processed audio signal has at least in an approximation the target time-domain envelope and a spectral envelope determined by the sequence of frequency-domain frames.


Owner:FRAUNHOFER GESELLSCHAFT ZUR FOERDERUNG DER ANGEWANDTEN FORSCHUNG EV
Frequency domain blind separation method and system with low complexity
ActiveCN110010148AGuaranteed accuracyEasy to initializeSpeech analysisTime domainComputation complexity
The invention discloses a frequency domain blind separation method and a frequency domain blind separation system with low complexity. The method comprises the following steps: acquiring frequency domain separation signals collected by a microphone array; carrying out correlation analysis on the separation signals of the current frequency point and the pervious frequency point, thus completing thelocal sorting of the separation signal of each frequency point; carrying out correlation analysis on the separation signal of each frequency point after local sorting and the global central point, thus completing the global sorting of the separation signal of each frequency point; carrying out amplitude adjustment on the separation signals after global sorting; and carrying out Fourier transformon the adjusted separation signals, thus obtaining the separation signals of the time domain. With the method combining local sorting with global sorting provided by the invention, the accuracy and robustness of separation can be improved, meanwhile, the iteration times of the sorting process is reduced, and the computation complexity is relatively low.


Owner:INST OF ACOUSTICS CHINESE ACAD OF SCI
Inertial navigation origin positioning method and system based on UWB ranging
ActiveCN106123895AEasy to initializeHigh system flexibilityNavigation by speed/acceleration measurementsPositioning equipmentEnvironmental geology
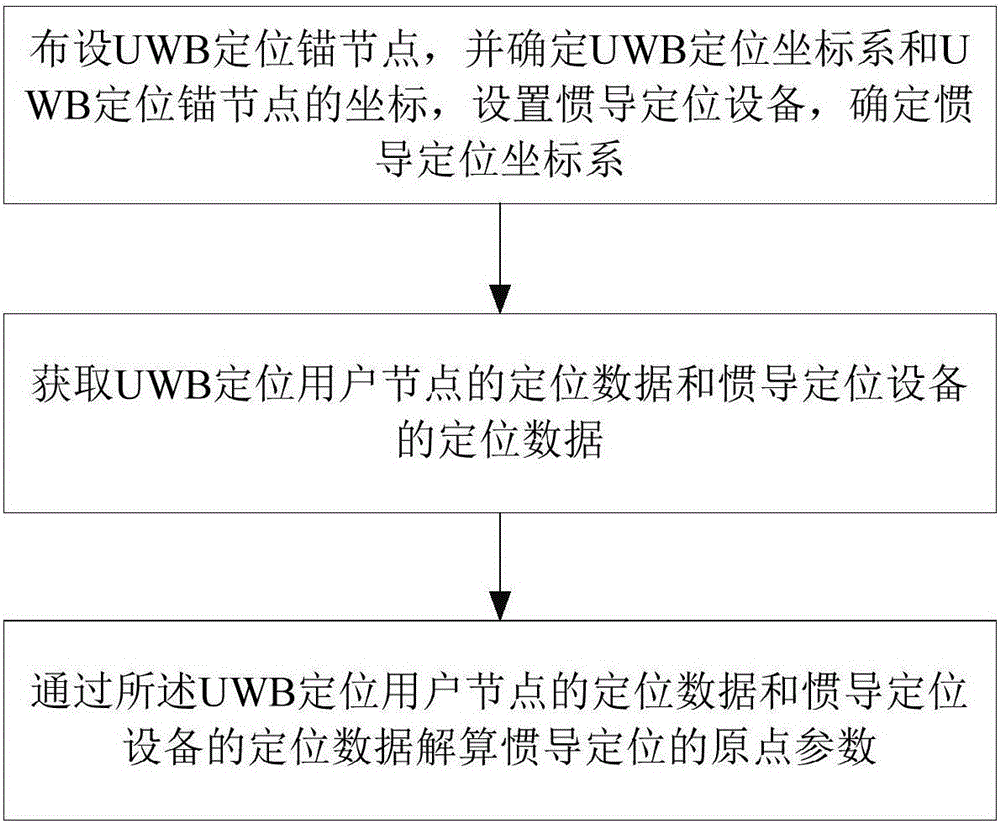
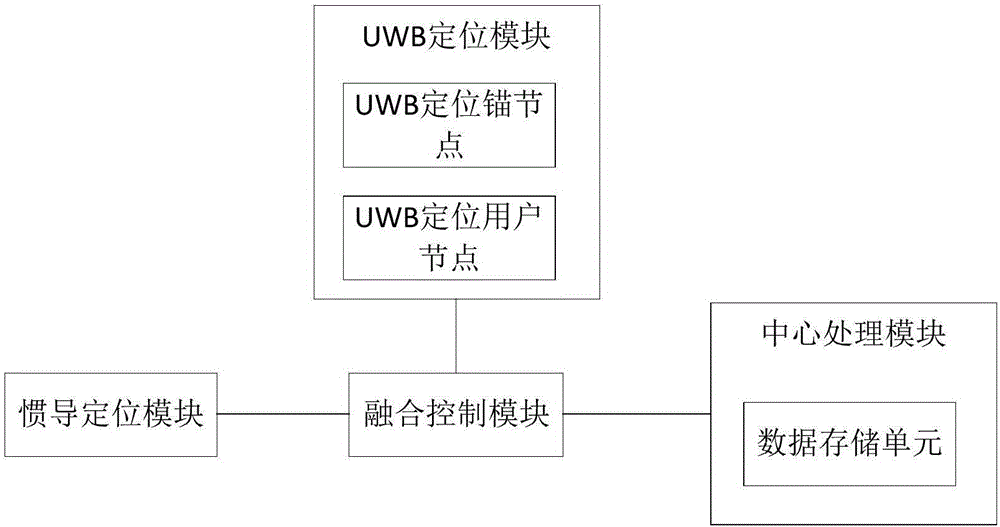
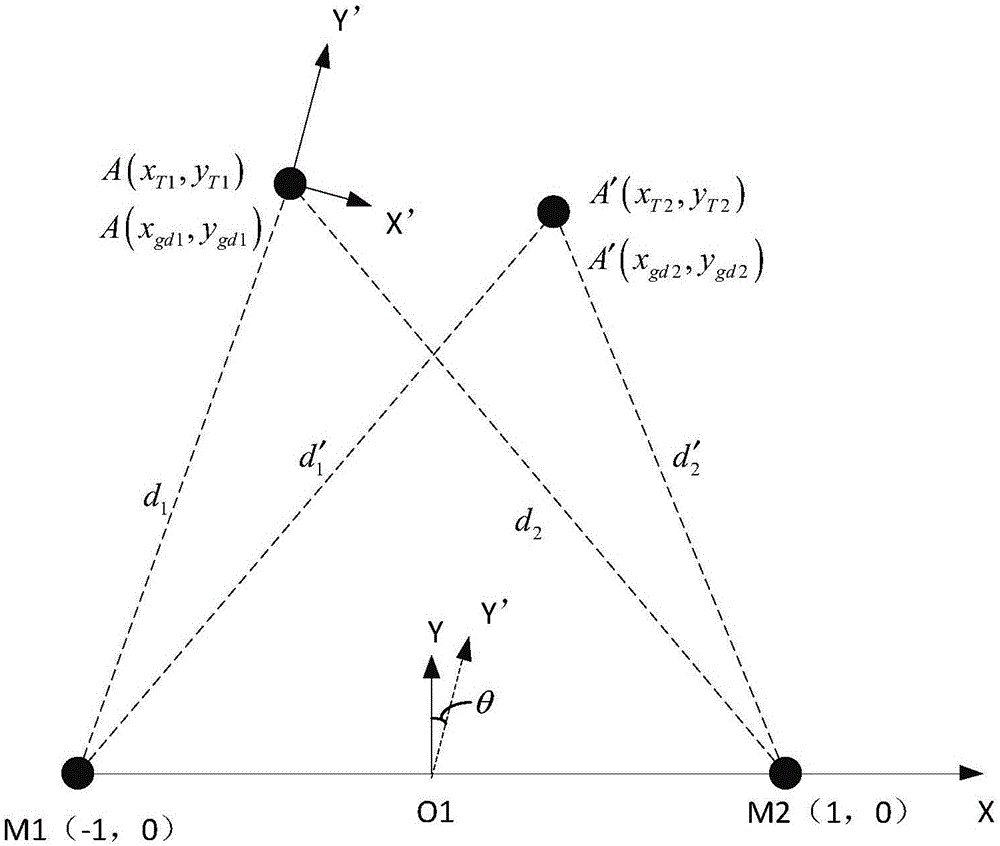
The invention discloses an inertial navigation origin positioning method and system based on UWB ranging. The method includes the steps that S1, UWB positioning anchor nodes are distributed, a UWB positioning coordinate system and coordinates of the UWB positioning anchor nodes are determined, inertial navigation positioning equipment is arranged, and an inertial navigation positioning coordinate system is determined; S2, positioning data of UWB positioning user nodes and positioning data of the inertial navigation positioning equipment are acquired; S3, inertial navigation positioning origin parameters are calculated according to the positioning data of UWB positioning user nodes and the positioning data of the inertial navigation positioning equipment. The system comprises a UWB positioning module, an inertial navigation positioning module, a fusion control module and a central processing module. The method and system have the advantages that during initialization of the inertial navigation equipment, the origin position and direction of the inertial navigation equipment can be selected at will, the initialization difficulty of the inertial navigation equipment is low, and the system is high in flexibility, movable and easy to operate, and can be conveniently suitable for various indoor and outdoor environments.
Owner:上海瀚界科技发展有限公司
Chinese text abstract generation method based on sequence-to-sequence model
ActiveCN111078866ADifficulty of SimplificationAvoid piecing together duplicated resultsNeural architecturesSpecial data processing applicationsAlgorithmTheoretical computer science
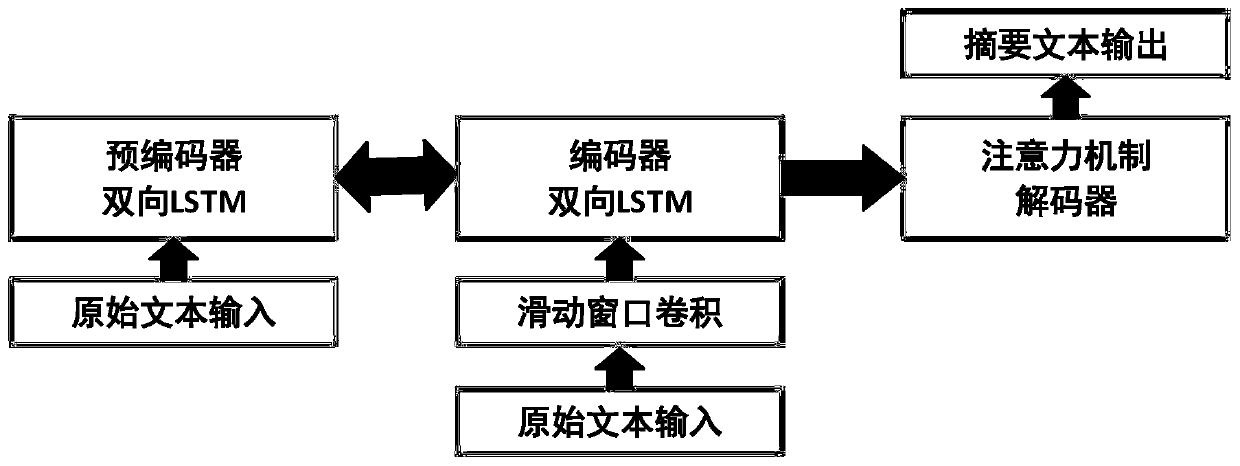
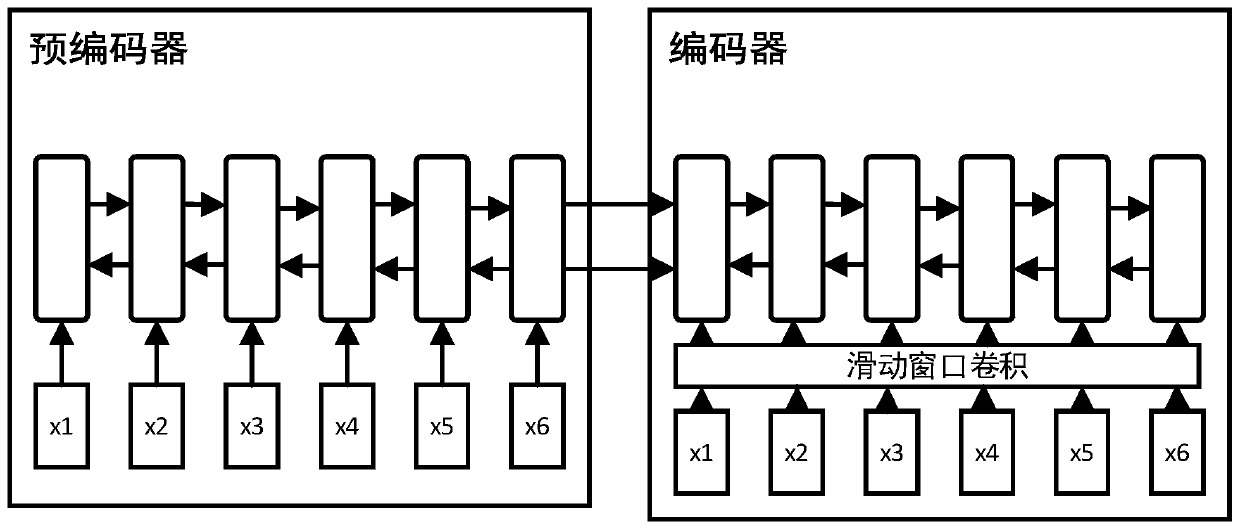
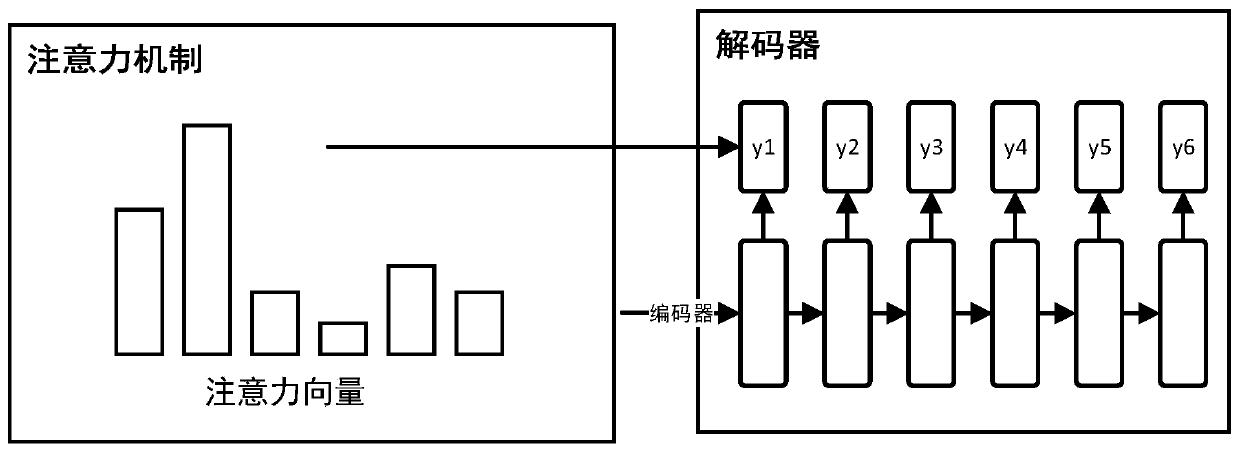
The invention discloses a Chinese text abstract generation method based on a sequence-to-sequence model, and the method comprises the steps: firstly carrying out the word segmentation of a text, filling the text to a fixed length, and carrying out the Gaussian random initialization of a word vector; encoding the text, inputting the encoded text into a bidirectional long short-term memory (LSTM) network, and taking the final output state as precoding; performing convolutional neural network (CNN) on the word vectors according to different window sizes, and outputting the word vectors as windowword vectors; constructing an encoder, constructing a bidirectional LSTM (Long Short Term Memory), taking precoding as an initialization parameter of the bidirectional LSTM, and taking a window word vector in the previous step as input; and constructing a decoder, and generating a text by using a one-way LSTM and combining an attention mechanism. According to the method, a traditional encoder froma sequence to a sequence model is improved, so that the model can obtain more original text information in an encoding stage, a better text abstract is finally decoded, and a word vector with smallerfine granularity is used, so that the method is more suitable for a Chinese text.
Owner:SOUTH CHINA UNIV OF TECH
Indoor positioning system and method based on MNL probability identification and positioning model establishing system
ActiveCN103476113AHigh precisionGuaranteed stabilityWireless communicationSimulationInformation acquisition
The invention discloses an indoor positioning system and method based on MNL probability identification. The system comprises an MNL positioning model establishing module, a wireless network information acquiring module and a wireless network data comparison module, wherein the MNL positioning model establishing module is used for establishing an MNL positioning model, fingerprint wireless information corresponding to all fingerprint points is used for generating the probability-based MNL discrete model, the model is described with a series of random functions and is written into a center database, the wireless network data comparison module is used for comparing wireless network information of set electronic equipment with the MNL positioning model and the fingerprint wireless information, and then combinatorial computing is carried out on a series of fingerprint point coordinates with the maximum probability value to judge whether the set electronic equipment is located at the position where a fingerprint point with the largest similarity is located. The indoor positioning system and method based on the MNL probability identification can improve the accuracy of indoor positioning, and especially guarantees the stability and interference resistance of indoor positioning under the condition that the WIFI signal is lost and the environment changes suddenly.


Owner:SHANGHAI WANCHANG TRANSPORTATION TECH CO LTD
Magnetic random access memory and initializing method for the same
ActiveUS8174873B2Initialize the magnetization state with comparative easeEasy stateMagnetic-field-controlled resistorsSolid-state devicesRandom access memoryMagnetization
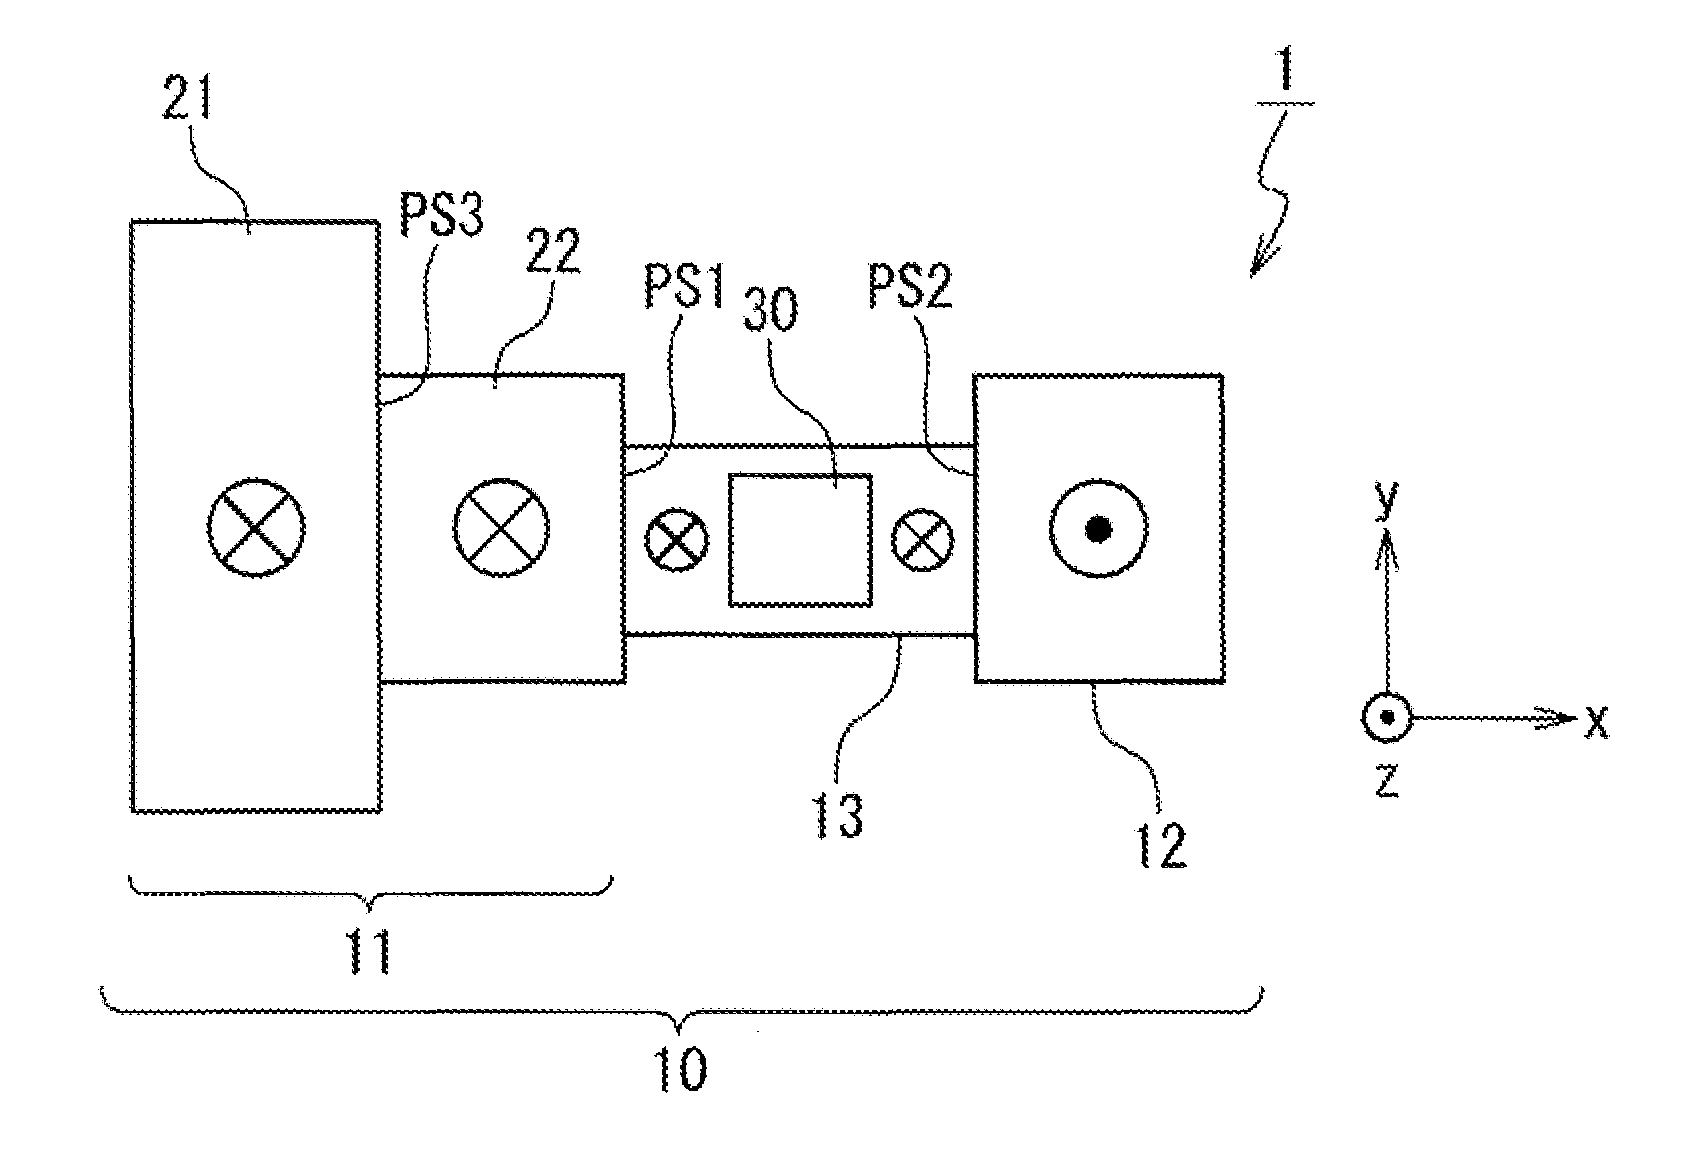
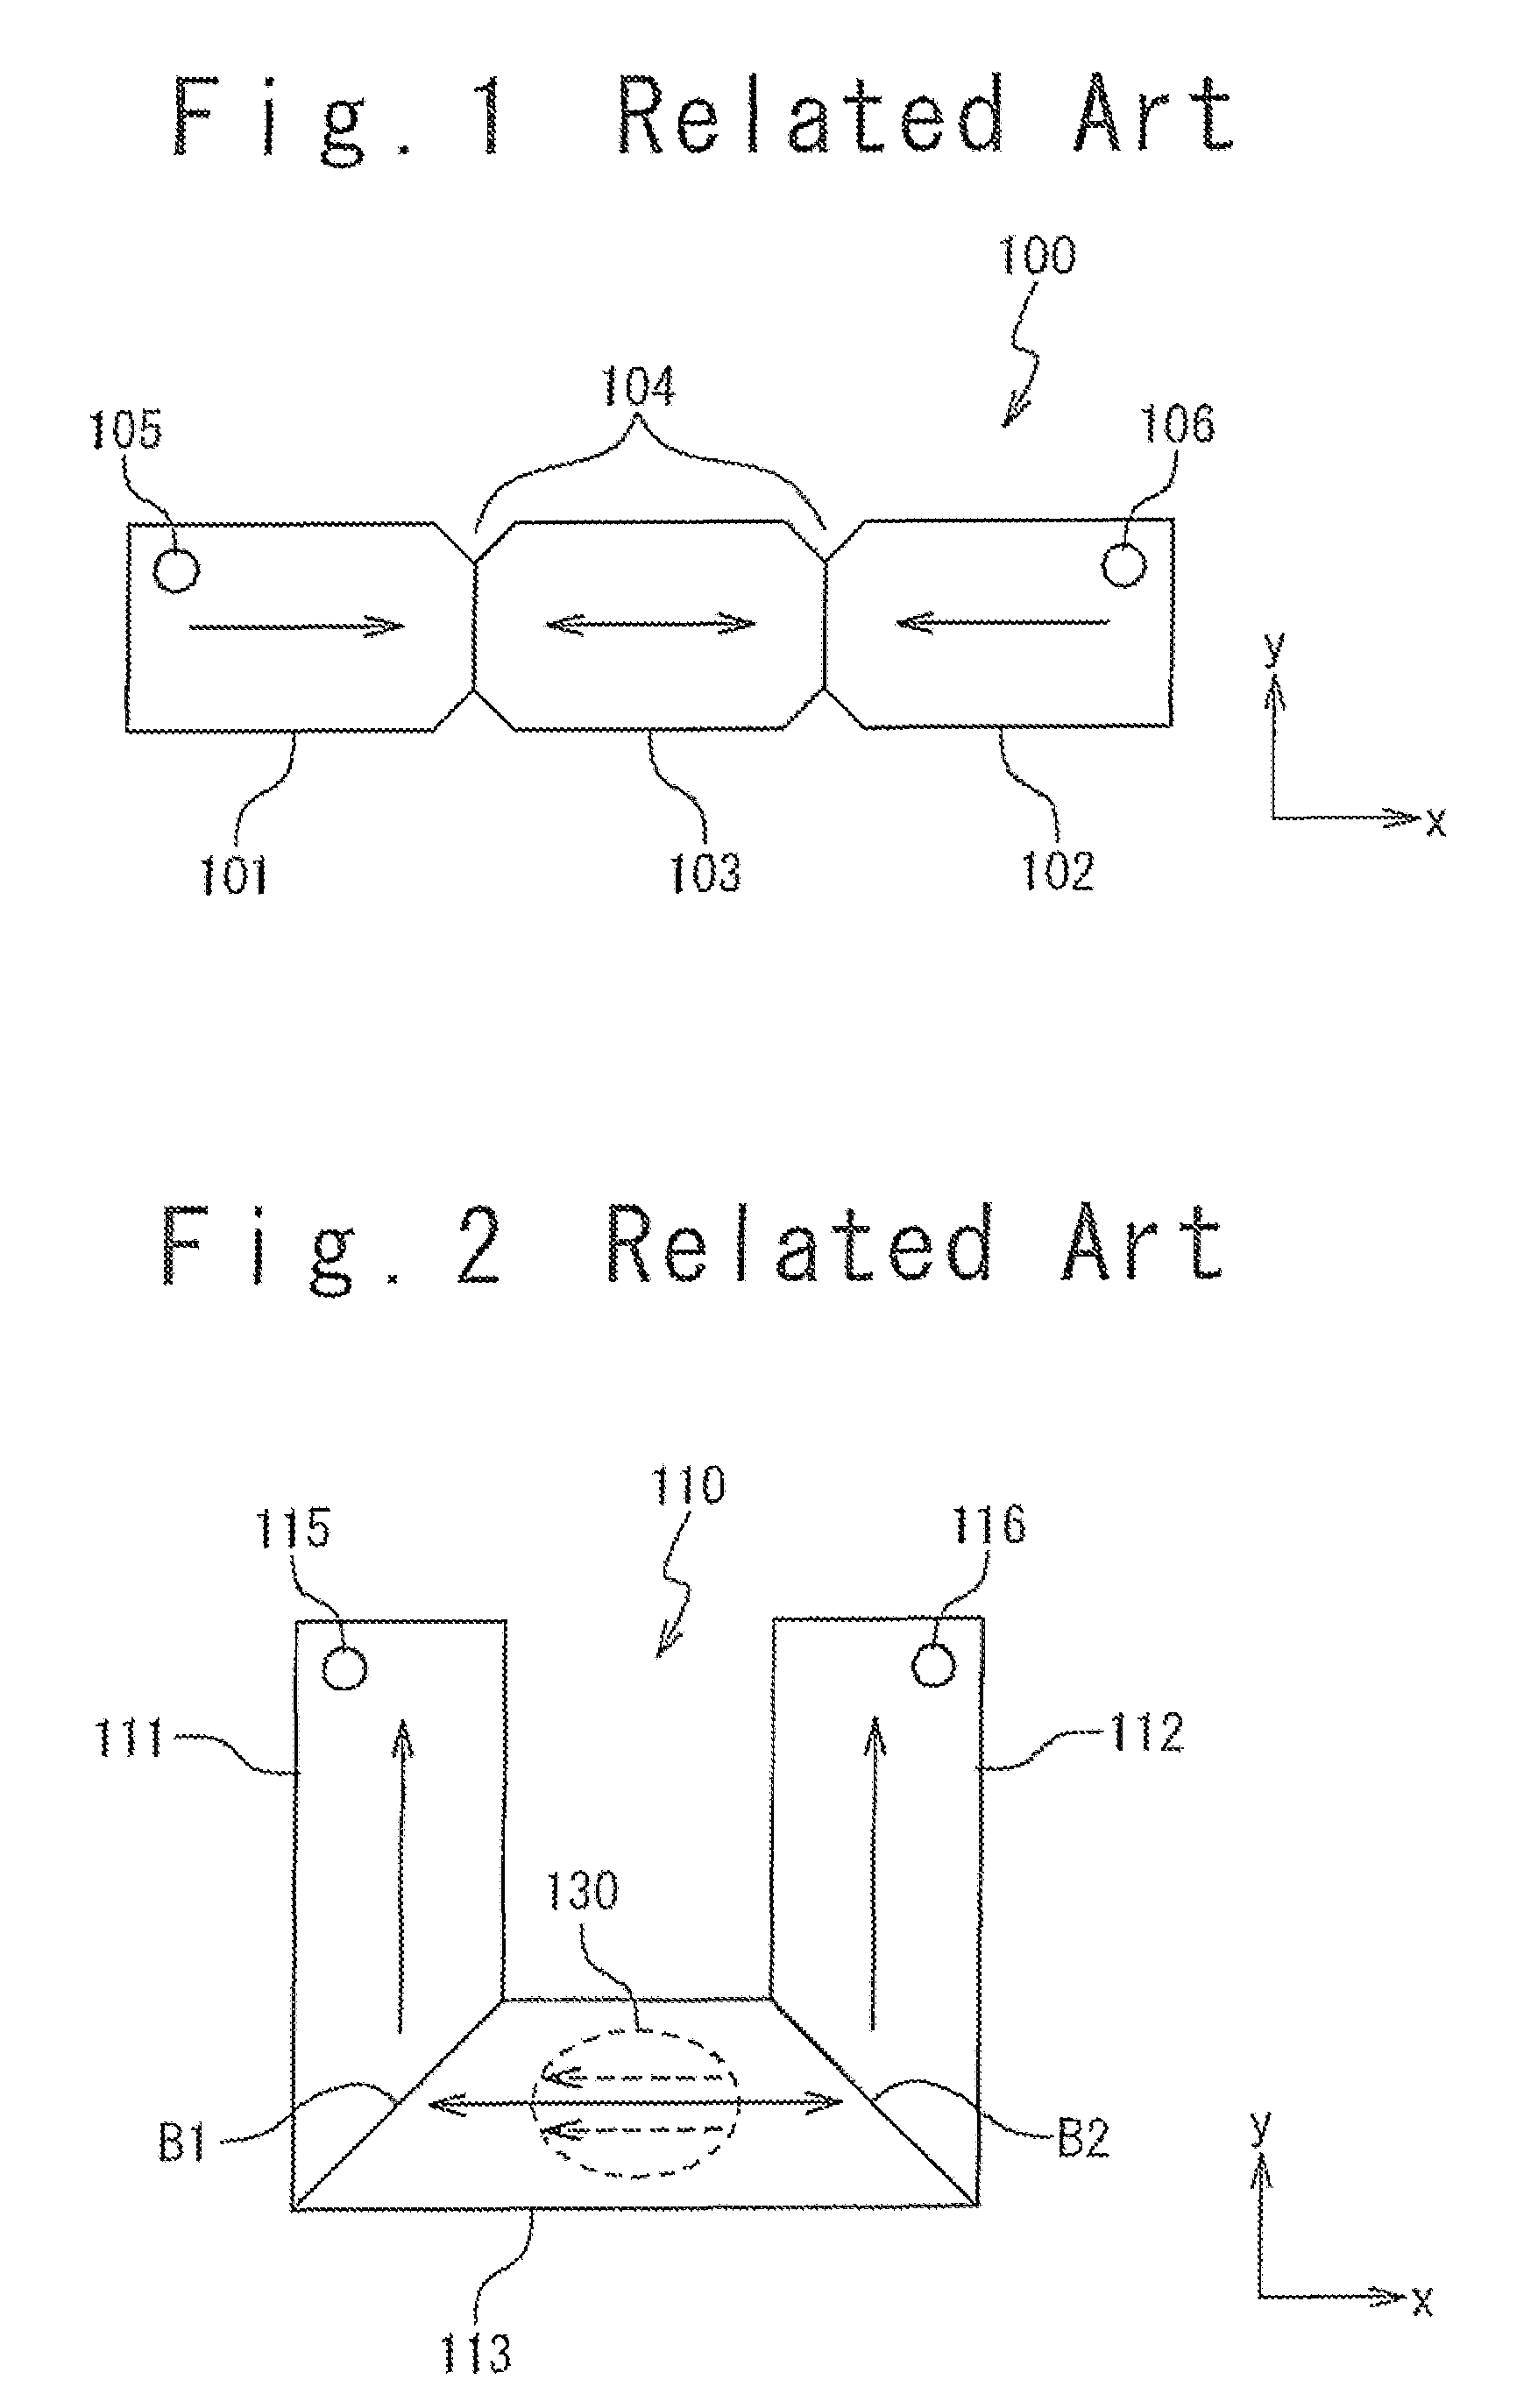
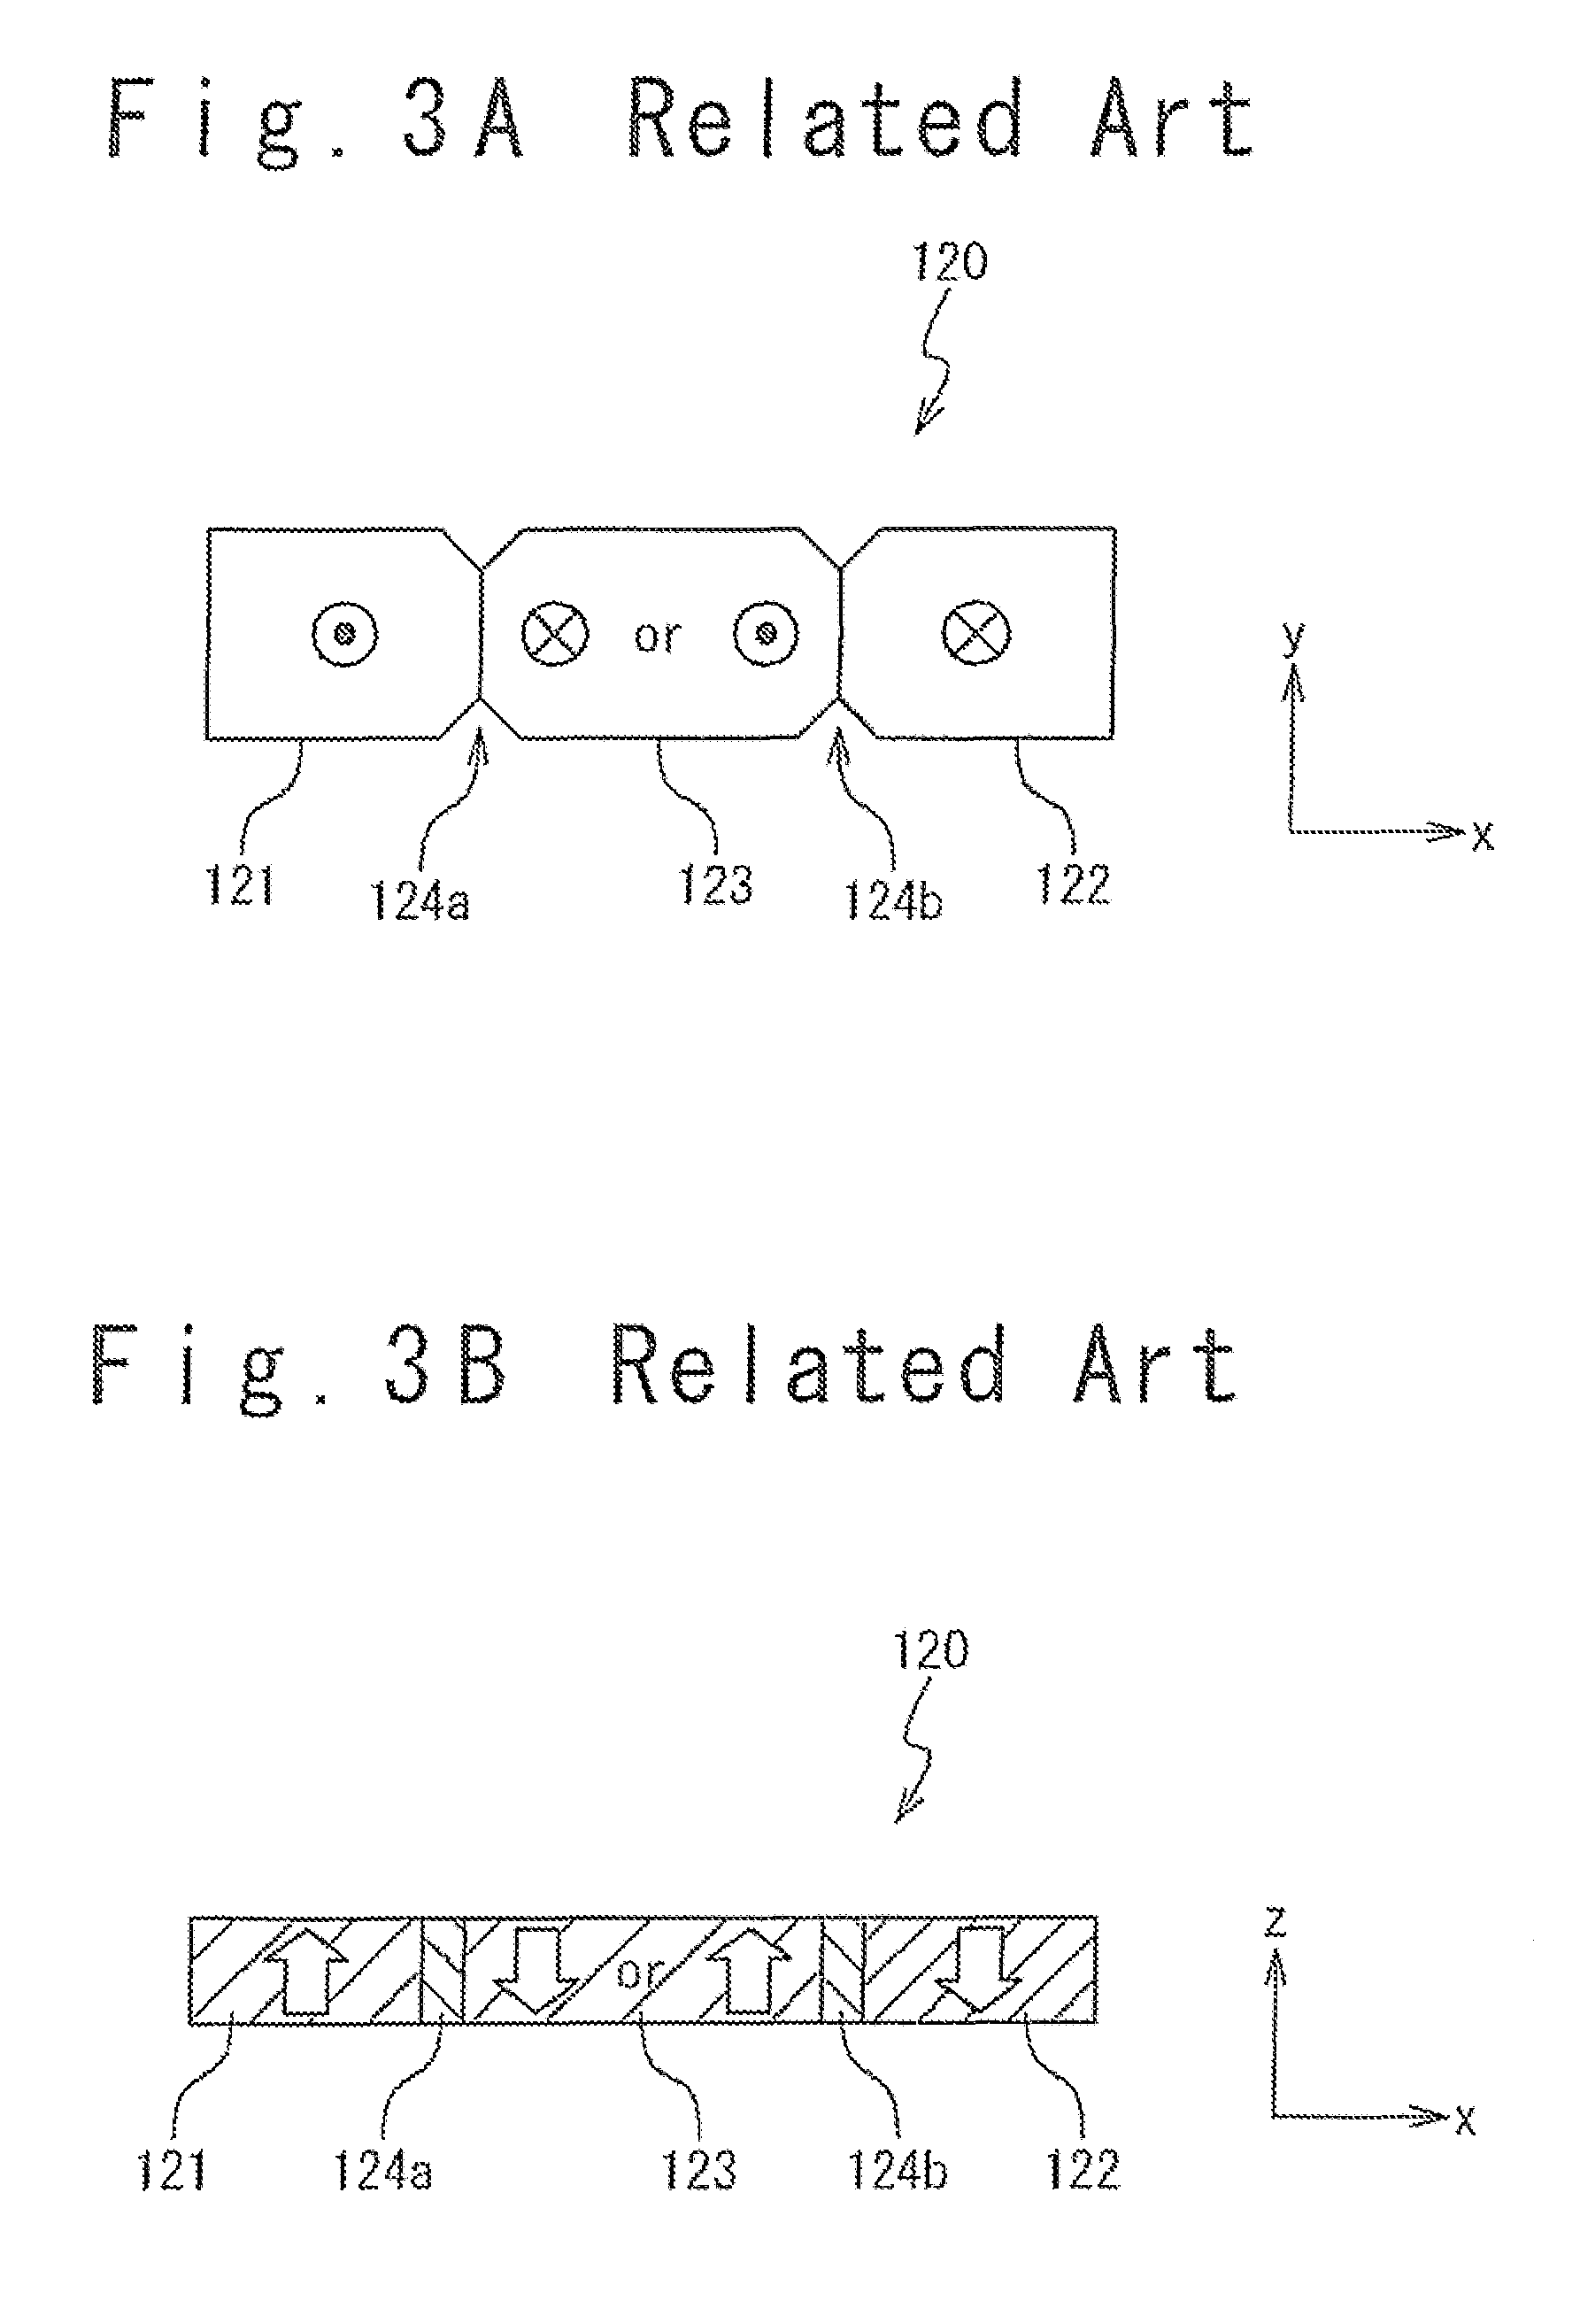
A domain wall motion type MRAM has: a magnetic recording layer 10 having perpendicular magnetic anisotropy; and a pair of terminals 51 and 52 used for supplying a current to the magnetic recording layer 10. The magnetic recording layer 10 has: a first magnetization region 11 connected to one of the pair of terminals; a second magnetization region 12 connected to the other of the pair of terminals; and a magnetization switching region 13 connecting between the first magnetization region 11 and the second magnetization region 12 and having reversible magnetization. A first pinning site PS1, by which the domain wall is trapped, is formed at a boundary between the first magnetization region 11 and the magnetization switching region 13. A second pinning site PS2, by which the domain wall is trapped, is formed at a boundary between the second magnetization region 12 and the magnetization switching region 13. A third pinning site PS3, by which the domain wall is trapped, is formed within the first magnetization region 11.
Owner:NEC CORP
System and method for grid MPI job allocation using file-based MPI initialization in grid computing system
InactiveUS20050198104A1Easy to initializeMultiple digital computer combinationsProgram loading/initiatingInitMiddleware
Disclosed is a file-based grid MPI job allocation system for a middleware-based grid computing system in which computers having a plurality of resources including an MPI program are distributed and connected to each other through a network, wherein the grid MPI job allocation system differentiates functions of a middleware and the MPI program, thereby achieving MPI initialization without intervention of a separate arbitration process. The job submission service module generates a file containing an address, a port number, etc. of each node, which are necessary for the MPI initialization, and sends the file to the job execution service module of the corresponding node. Each job execution service module executes the MPI job, and the MPI program waits for the generation of the file and then performs initialization by using the information in the file. The present invention clearly differentiates the jobs to be done by the MPI program and by the job submission service module in the middleware, thereby enabling the MPI program to be executed in the grid computing system regardless of the design of the middleware.


Owner:KOREA INST OF SCI & TECH INFORMATION
Dynamic token initializing method and device
ActiveCN102891753AImprove efficiencyImprove securityUser identity/authority verificationCiphertextCurrent time
The invention discloses a dynamic token initializing method, which comprises the following steps of: receiving and storing first data comprising a sequence number, current time and protection key information and decrypting the protection key information according to a fixed key to obtain a protection key; and receiving second data comprising a checking key ciphertext and a seed dispersion key ciphertext, decrypting the ciphertexts in the second data according to the protection key to obtain a checking key and a seed dispersion key and storing the checking key and the seed dispersion key. The invention also discloses a dynamic token initializing device. According to the invention, due to adoption of the method comprising the steps of receiving and storing the first data comprising the sequence number, the current time and the protection key information, obtaining the protection key according to the protection key information, acquiring the checking key and the seed dispersion key according to the protection key and storing the checking key and the seed dispersion key, the beneficial effect that manual input is not needed when a dynamic token is initialized is achieved, the dynamic token initializing efficiency and safety are improved and the dynamic token initializing process is more convenient.


Owner:北京明华联盟科技有限公司
Reproducing apparatus
InactiveUS20070014215A1Easy to initializeCombination recordingFilamentary/web record carriersComputer hardwareInformation data
A recording / reproducing unit for recording / reproducing information data on / from a recording medium, an initialization unit for initializing the recording medium in one of a first initialization mode in which information data recorded in all recording areas of the recording media is erased and a second initialization mode in which management data for information data recorded on the recording medium is erased from certain areas of the recording medium and erasion is not performed on other recording areas, and a control unit for controlling the initialization unit in accordance with an instruction to shut off a power of the apparatus during initialization, wherein processing by the initialization unit is changed between a case where the power-off instruction is received during initialization in the first initialization mode and a case where the power-off instruction is received during initialization in the second initialization mode.


Owner:CANON KK
Biped locomotion robot
InactiveUS6981562B2Small sizeEasy to analyzeProgramme-controlled manipulatorSpecial data processing applicationsMovement analysisEngineering
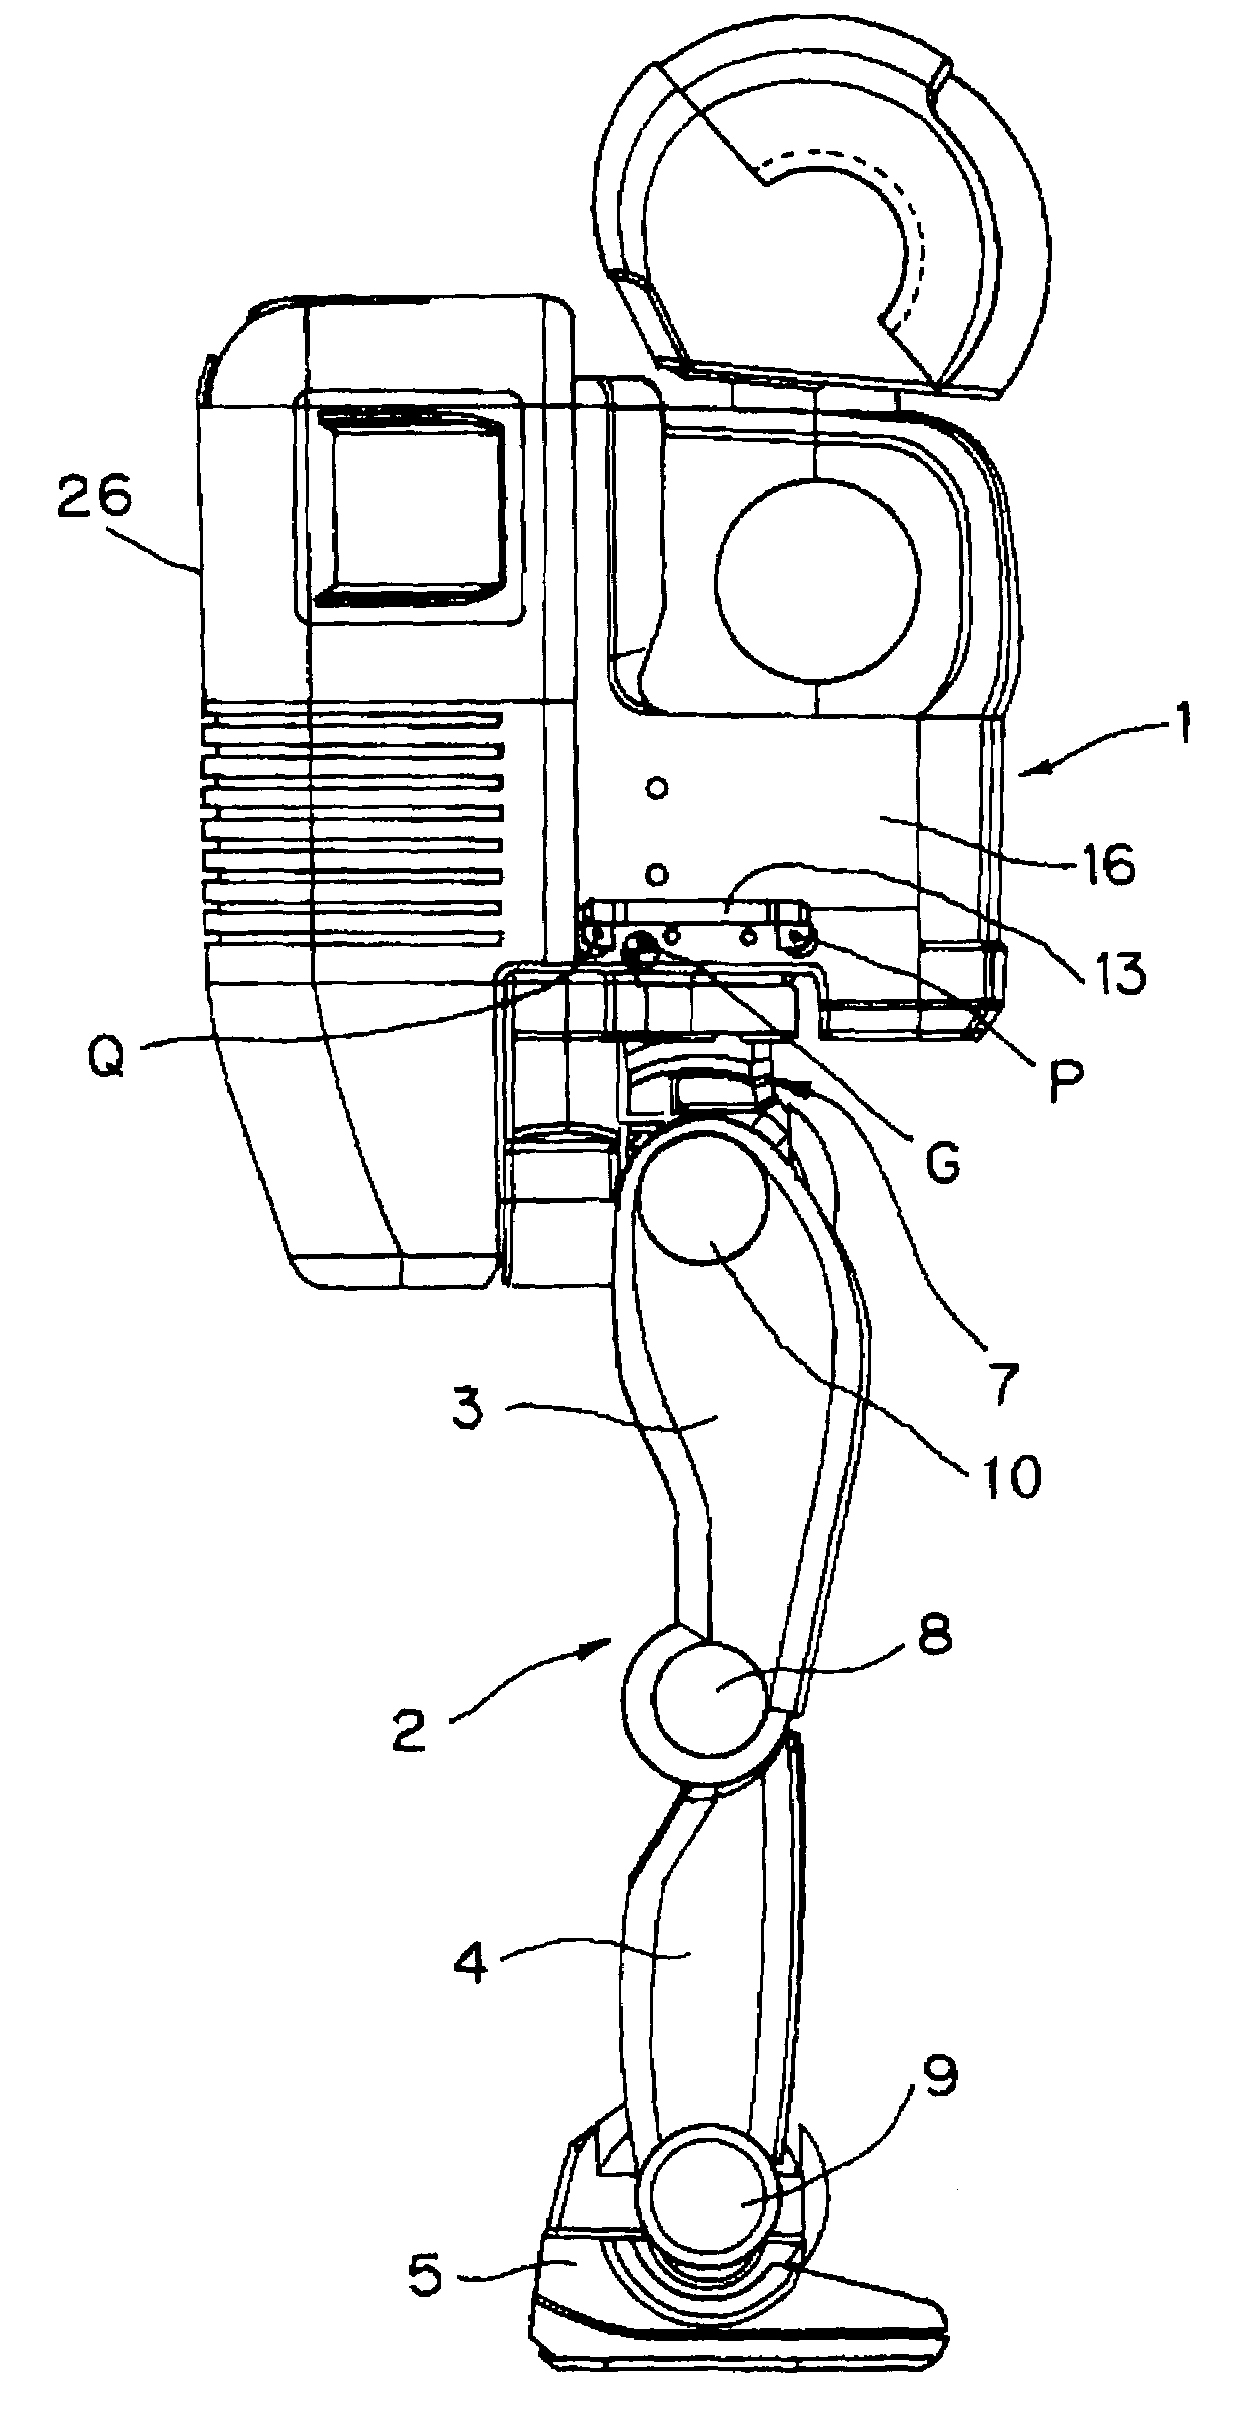
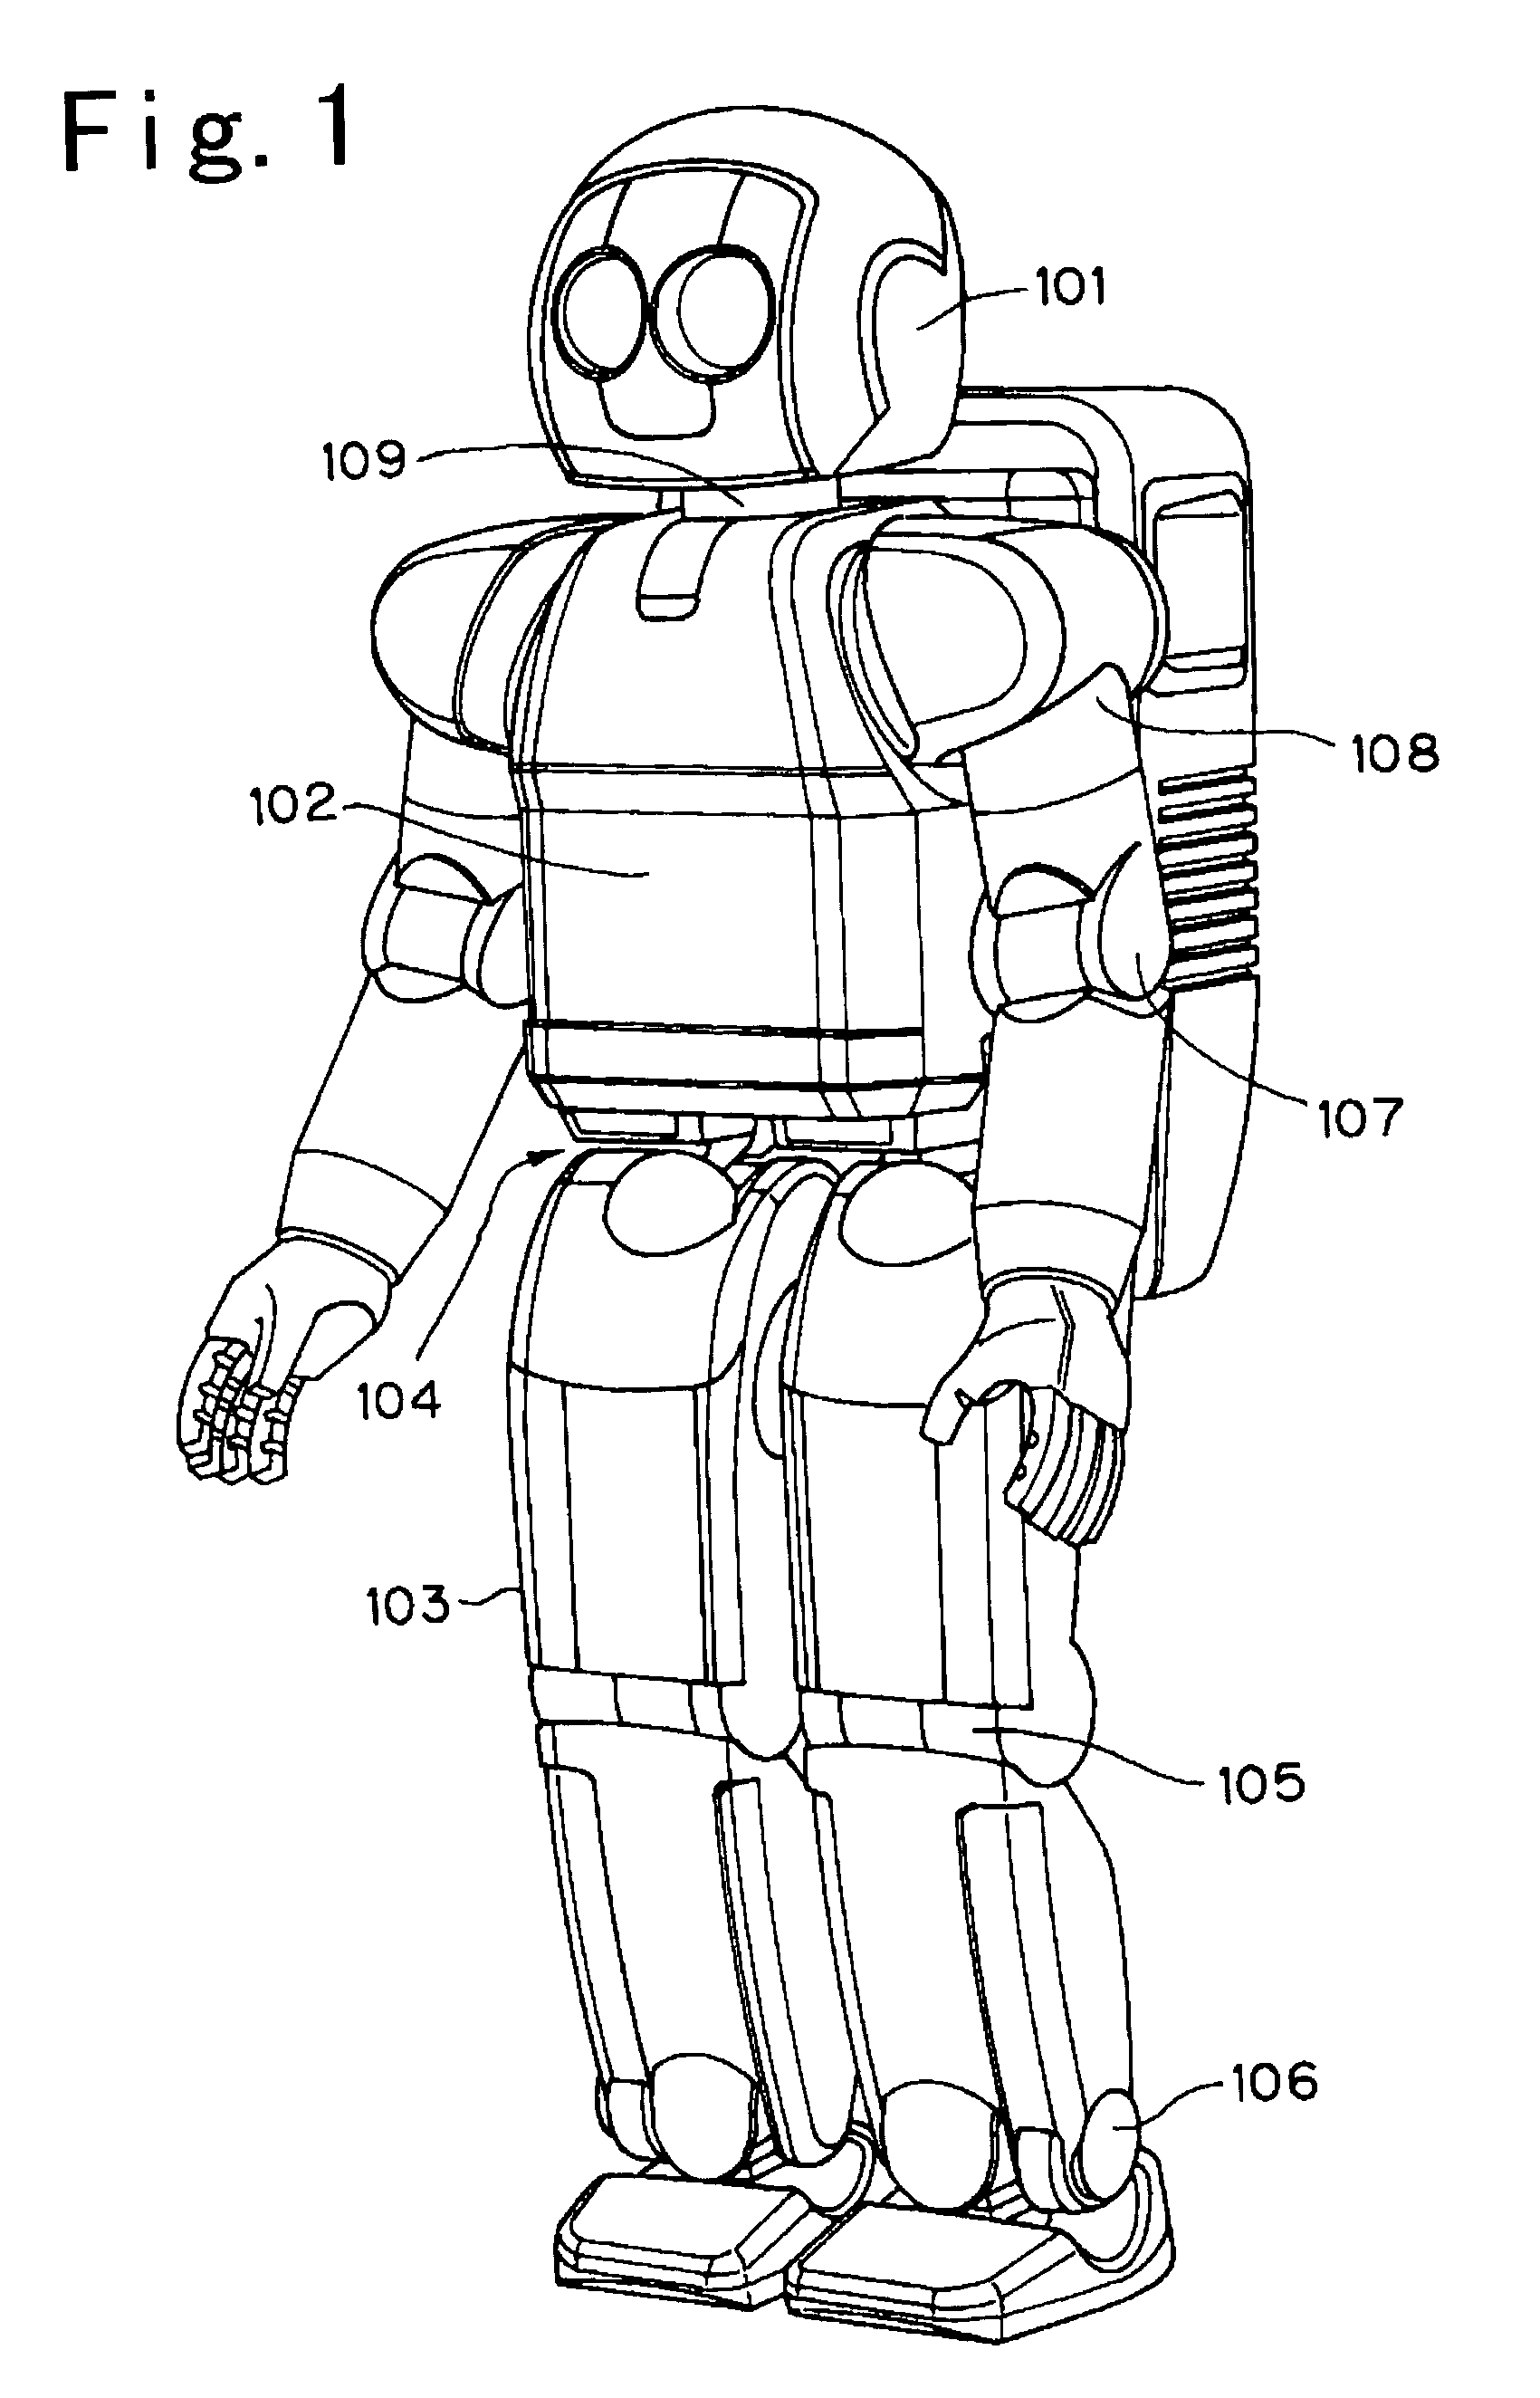
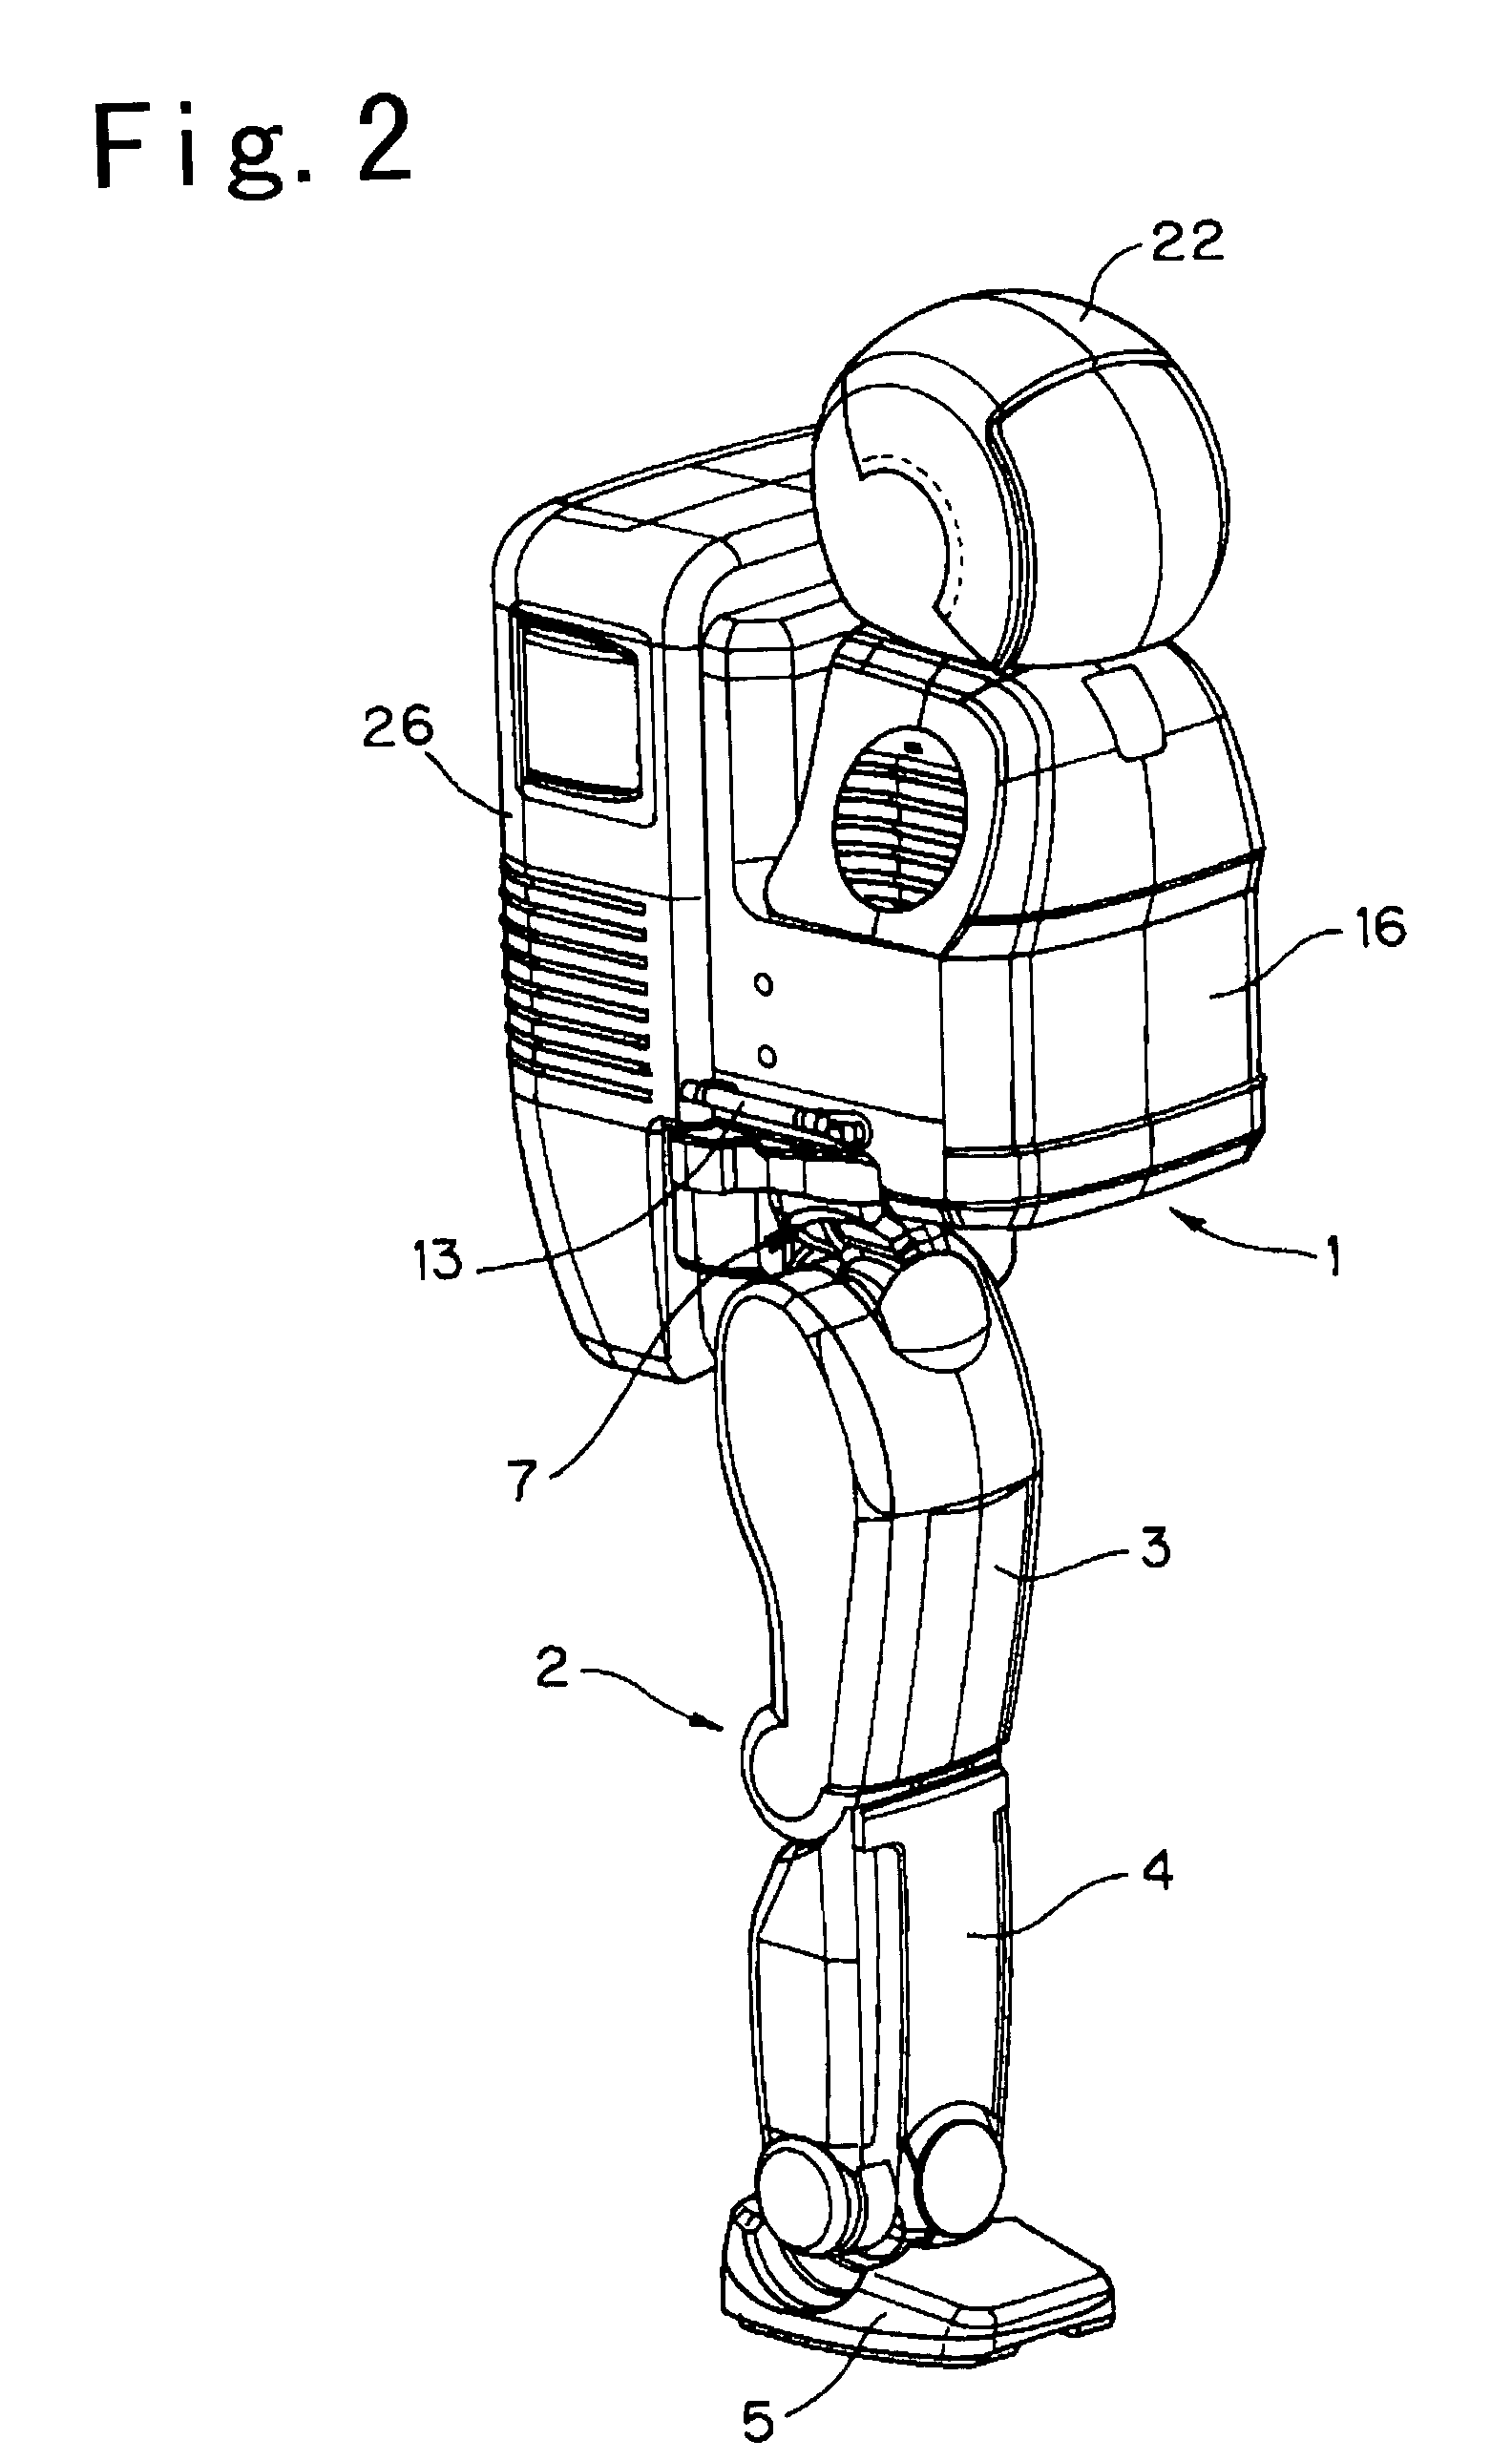
The movement analysis becomes easy and the control of all the movement systems is realized better through the initialization of the multiple coordinate systems. The fundamental body portion 6 is coupled to a foot portion 5 through a first joint portion 7, a first link 3, a second joint portion 8, a second link 4, and a third joint portion 9. The rigidity of the first link 3 is lower than that of the fundamental body portion 6, and the rigidity of the second link 4 is lower than that of the second link 4. It is possible to position the second link 4 and the foot portion 5 in a high precision to a mechanical origin which is predetermined to the fundamental body portion, for the reason of the rigidity relation. Handle portions 13 are coupled in two positions to the fundamental body portion 6. When the whole posture is initialized based on the mechanical origin, the center of gravity G of the whole robot is located between two vertical planes containing the two positions. In the initialization, a first joint portion 7, a second joint portion 8, and a third joint portion 9 are located between the two vertical planes. Thus, because the whole balance is taken, the origin adjustment is easy.
Owner:HONDA MOTOR CO LTD
Magnetic random access memory and initializing method for the same
ActiveUS20100315854A1Easy to initializeWrite currentMagnetic-field-controlled resistorsSolid-state devicesRandom access memoryMagnetization
A domain wall motion type MRAM has: a magnetic recording layer 10 having perpendicular magnetic anisotropy; and a pair of terminals 51 and 52 used for supplying a current to the magnetic recording layer 10. The magnetic recording layer 10 has: a first magnetization region 11 connected to one of the pair of terminals; a second magnetization region 12 connected to the other of the pair of terminals; and a magnetization switching region 13 connecting between the first magnetization region 11 and the second magnetization region 12 and having reversible magnetization. A first pinning site PS1, by which the domain wall is trapped, is formed at a boundary between the first magnetization region 11 and the magnetization switching region 13. A second pinning site PS2, by which the domain wall is trapped, is formed at a boundary between the second magnetization region 12 and the magnetization switching region 13. A third pinning site PS3, by which the domain wall is trapped, is formed within the first magnetization region 11.


Owner:NEC CORP
Method for starting a communication system, a communication system having a communication medium and a plurality of subscribers connected thereto, and subscribers of such a communication system
InactiveUS20100061404A1Easy to startEasy to initializeSynchronisation arrangementTime-division multiplexCommunications systemTransmission channel
A communication system having a communication medium and at least two subscribers connected thereto is described; the communication system being designed for transmitting data among the subscribers via the communication medium in communication frames of communication cycles via a time-triggered protocol. To accelerate the start of the communication system before the actual data transmission, the communication system has a device for generating at least two different synchronization frames per communication cycle and per channel, in at least one of the subscribers, e.g., in the node AB. For example, the device is designed as two separate communication controllers per transmission channel. As an alternative, the device may also be designed as a simple logic circuit, a so-called application-specific standard product. For generating the at least two different synchronization frames per communication cycle, the subscriber is designed as an active star coupler of the communication system. Data transmission in the communication system is preferably performed using the FlexRay protocol.


Owner:ROBERT BOSCH GMBH
Multi-modal nuclear magnetic image cerebral arterial thrombosis lesion segmentation method based on convolutional neural network
InactiveCN111862136AEffective segmentationShorten the timeImage enhancementImage analysisCerebral arterial thrombosisTest set
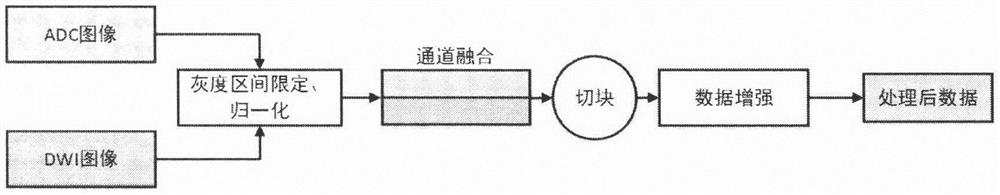
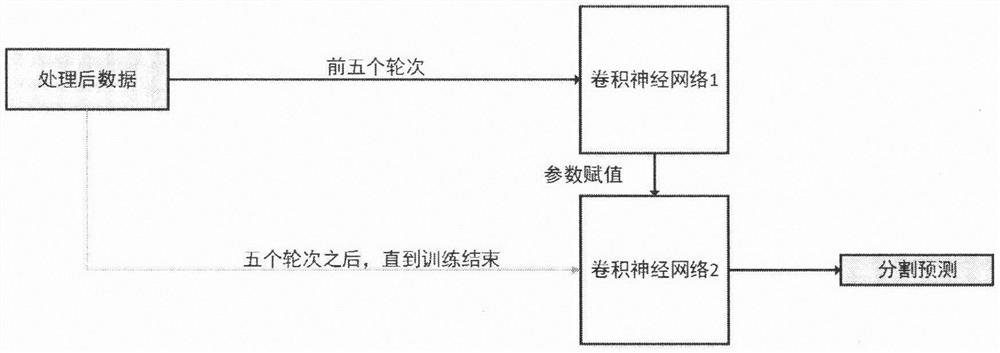
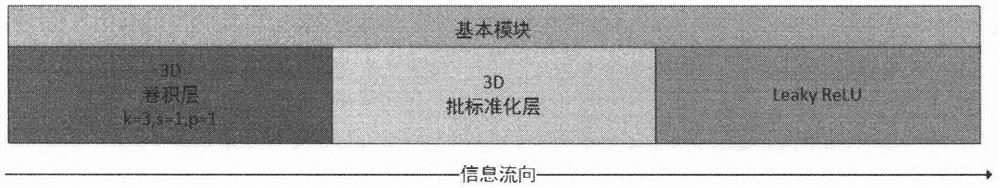
The invention discloses a multi-mode nuclear magnetic image cerebral arterial thrombosis lesion segmentation method based on a convolutional neural network. The method comprises the steps of designinga deep convolutional neural network 1 based on an original framework of a 3D U-Net network; basic modules based on a 3 * 3 * 3 convolution layer and a batch standardization layer; a 3D deformable convolution module based on a 3 * 3 * 3 convolution layer and trilinear interpolation; a cascade deformation module based on the 3D deformable convolution module and the basic module; constructing a deepconvolutional neural network 2 based on the 3D U-Net network and the cascaded deformation module; inputting the processed data into a neural network 1 for pre-training; assigning a weight obtained bypre-training to a neural network 2 for training; and verifying the segmentation effect on the test set of the pixel-level label. The invention provides an automatic labeling method for ischemic stroke lesion segmentation, so that the cost of labeling data is greatly reduced, the engineering operability is enhanced to a certain extent, and doctors are assisted in clinical diagnosis of ischemic stroke patients.
Owner:NANKAI UNIV
System and method for phase-locked loop initialization
InactiveUS7265634B2Introduce jitterEasy to initializePulse automatic controlGenerator starterPhase locked loop circuitEngineering
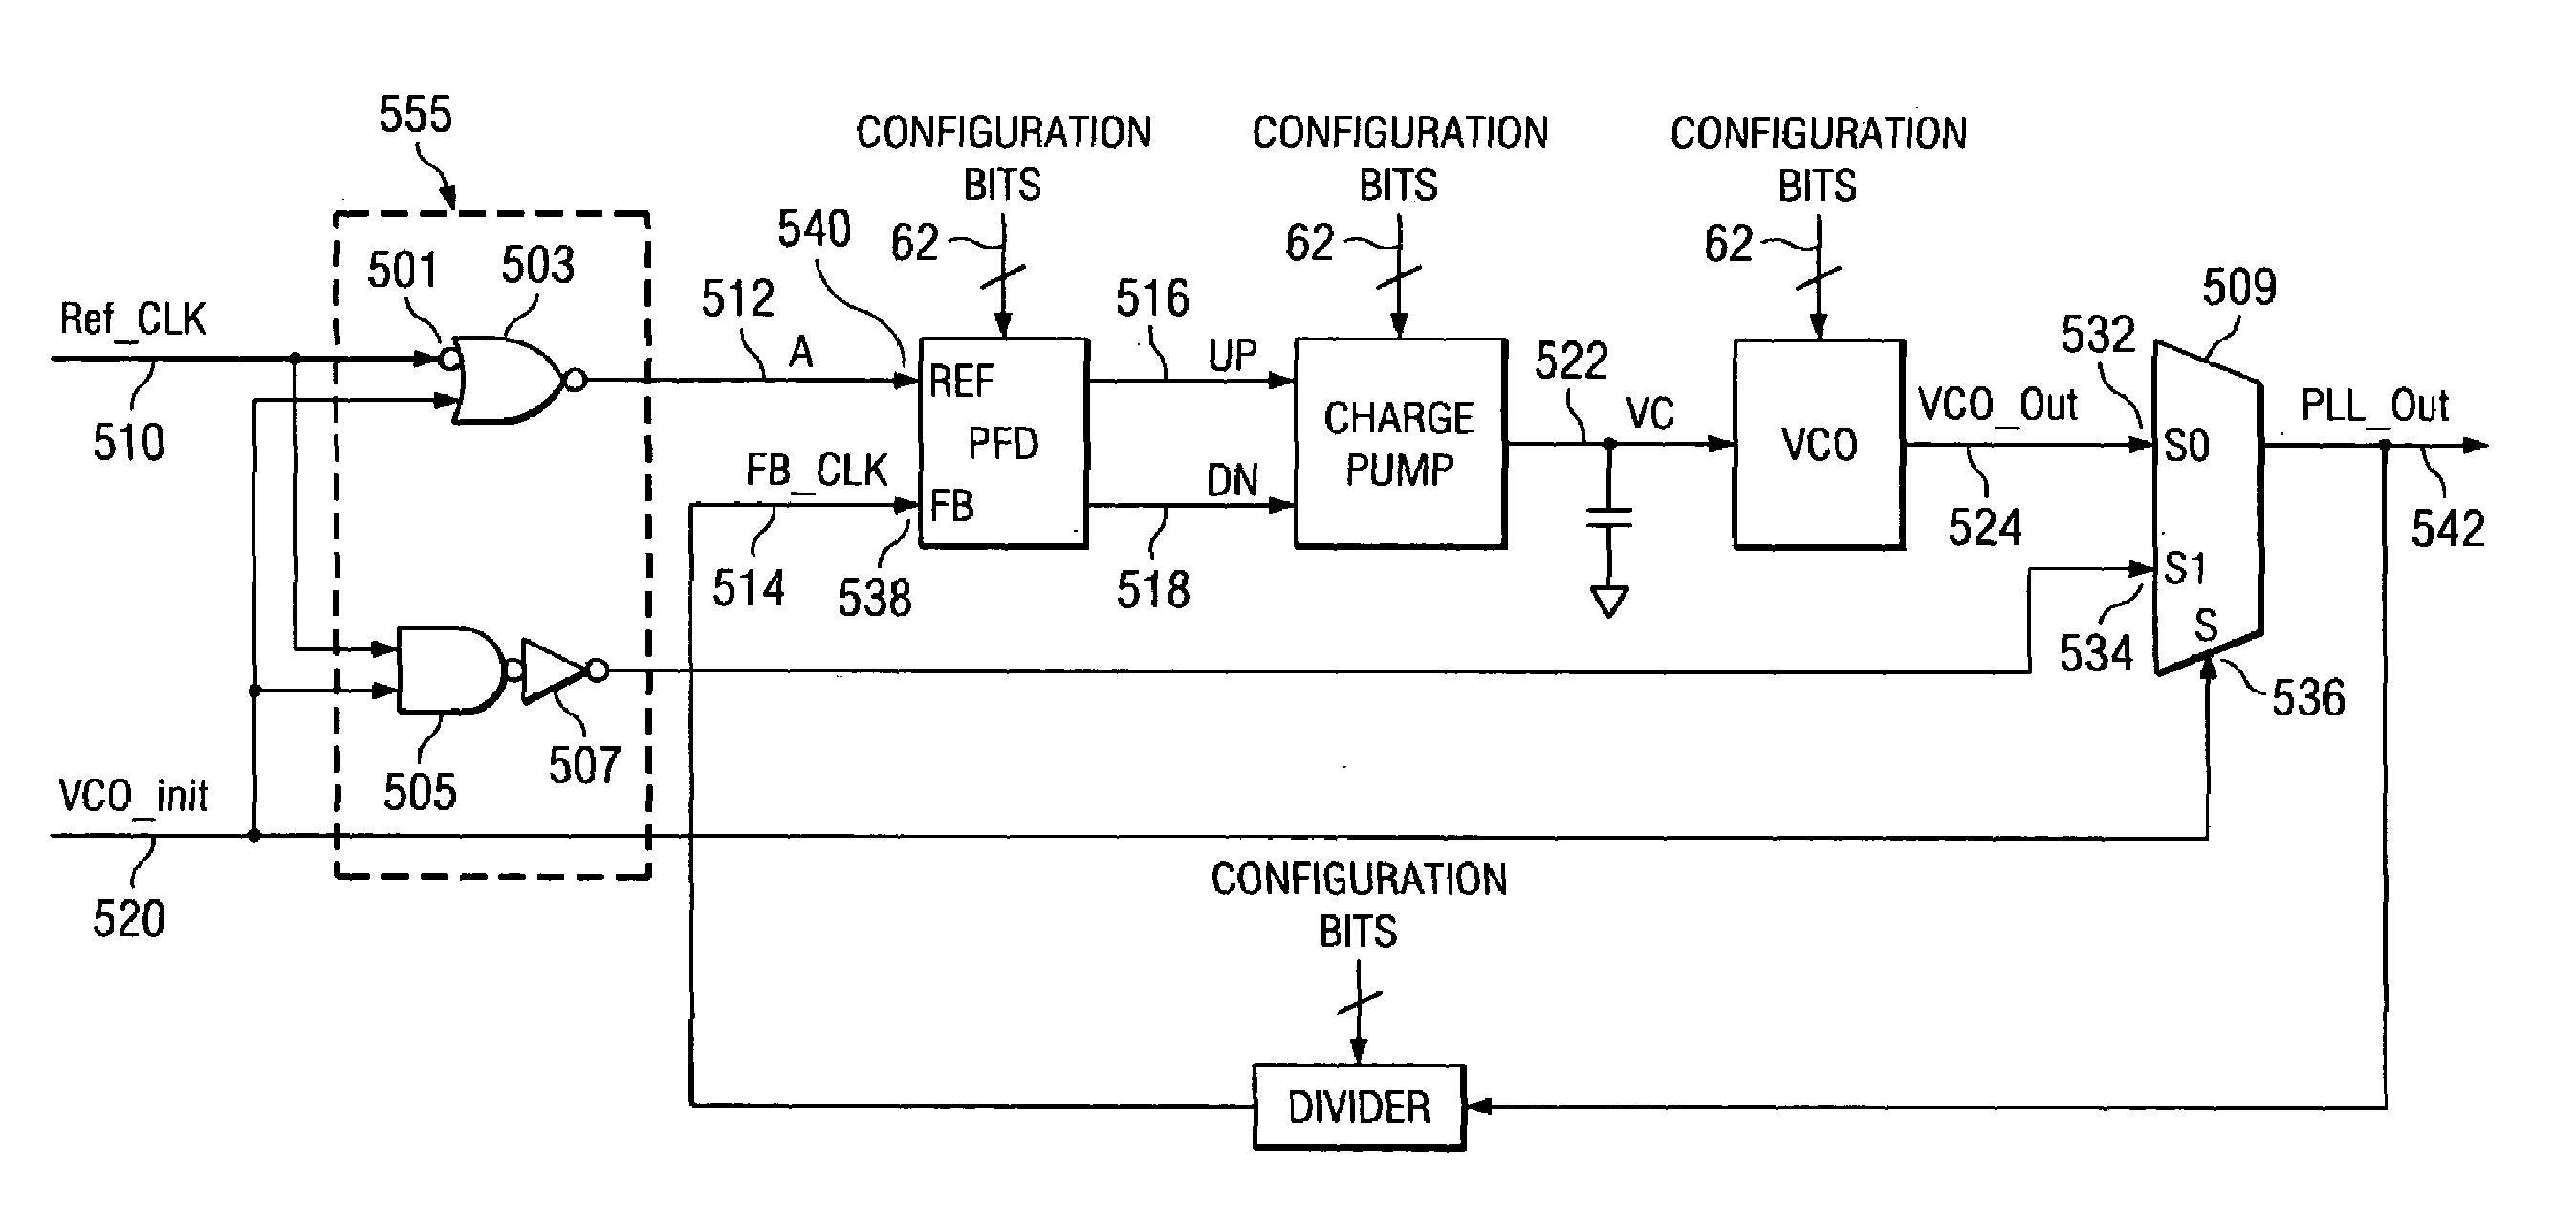
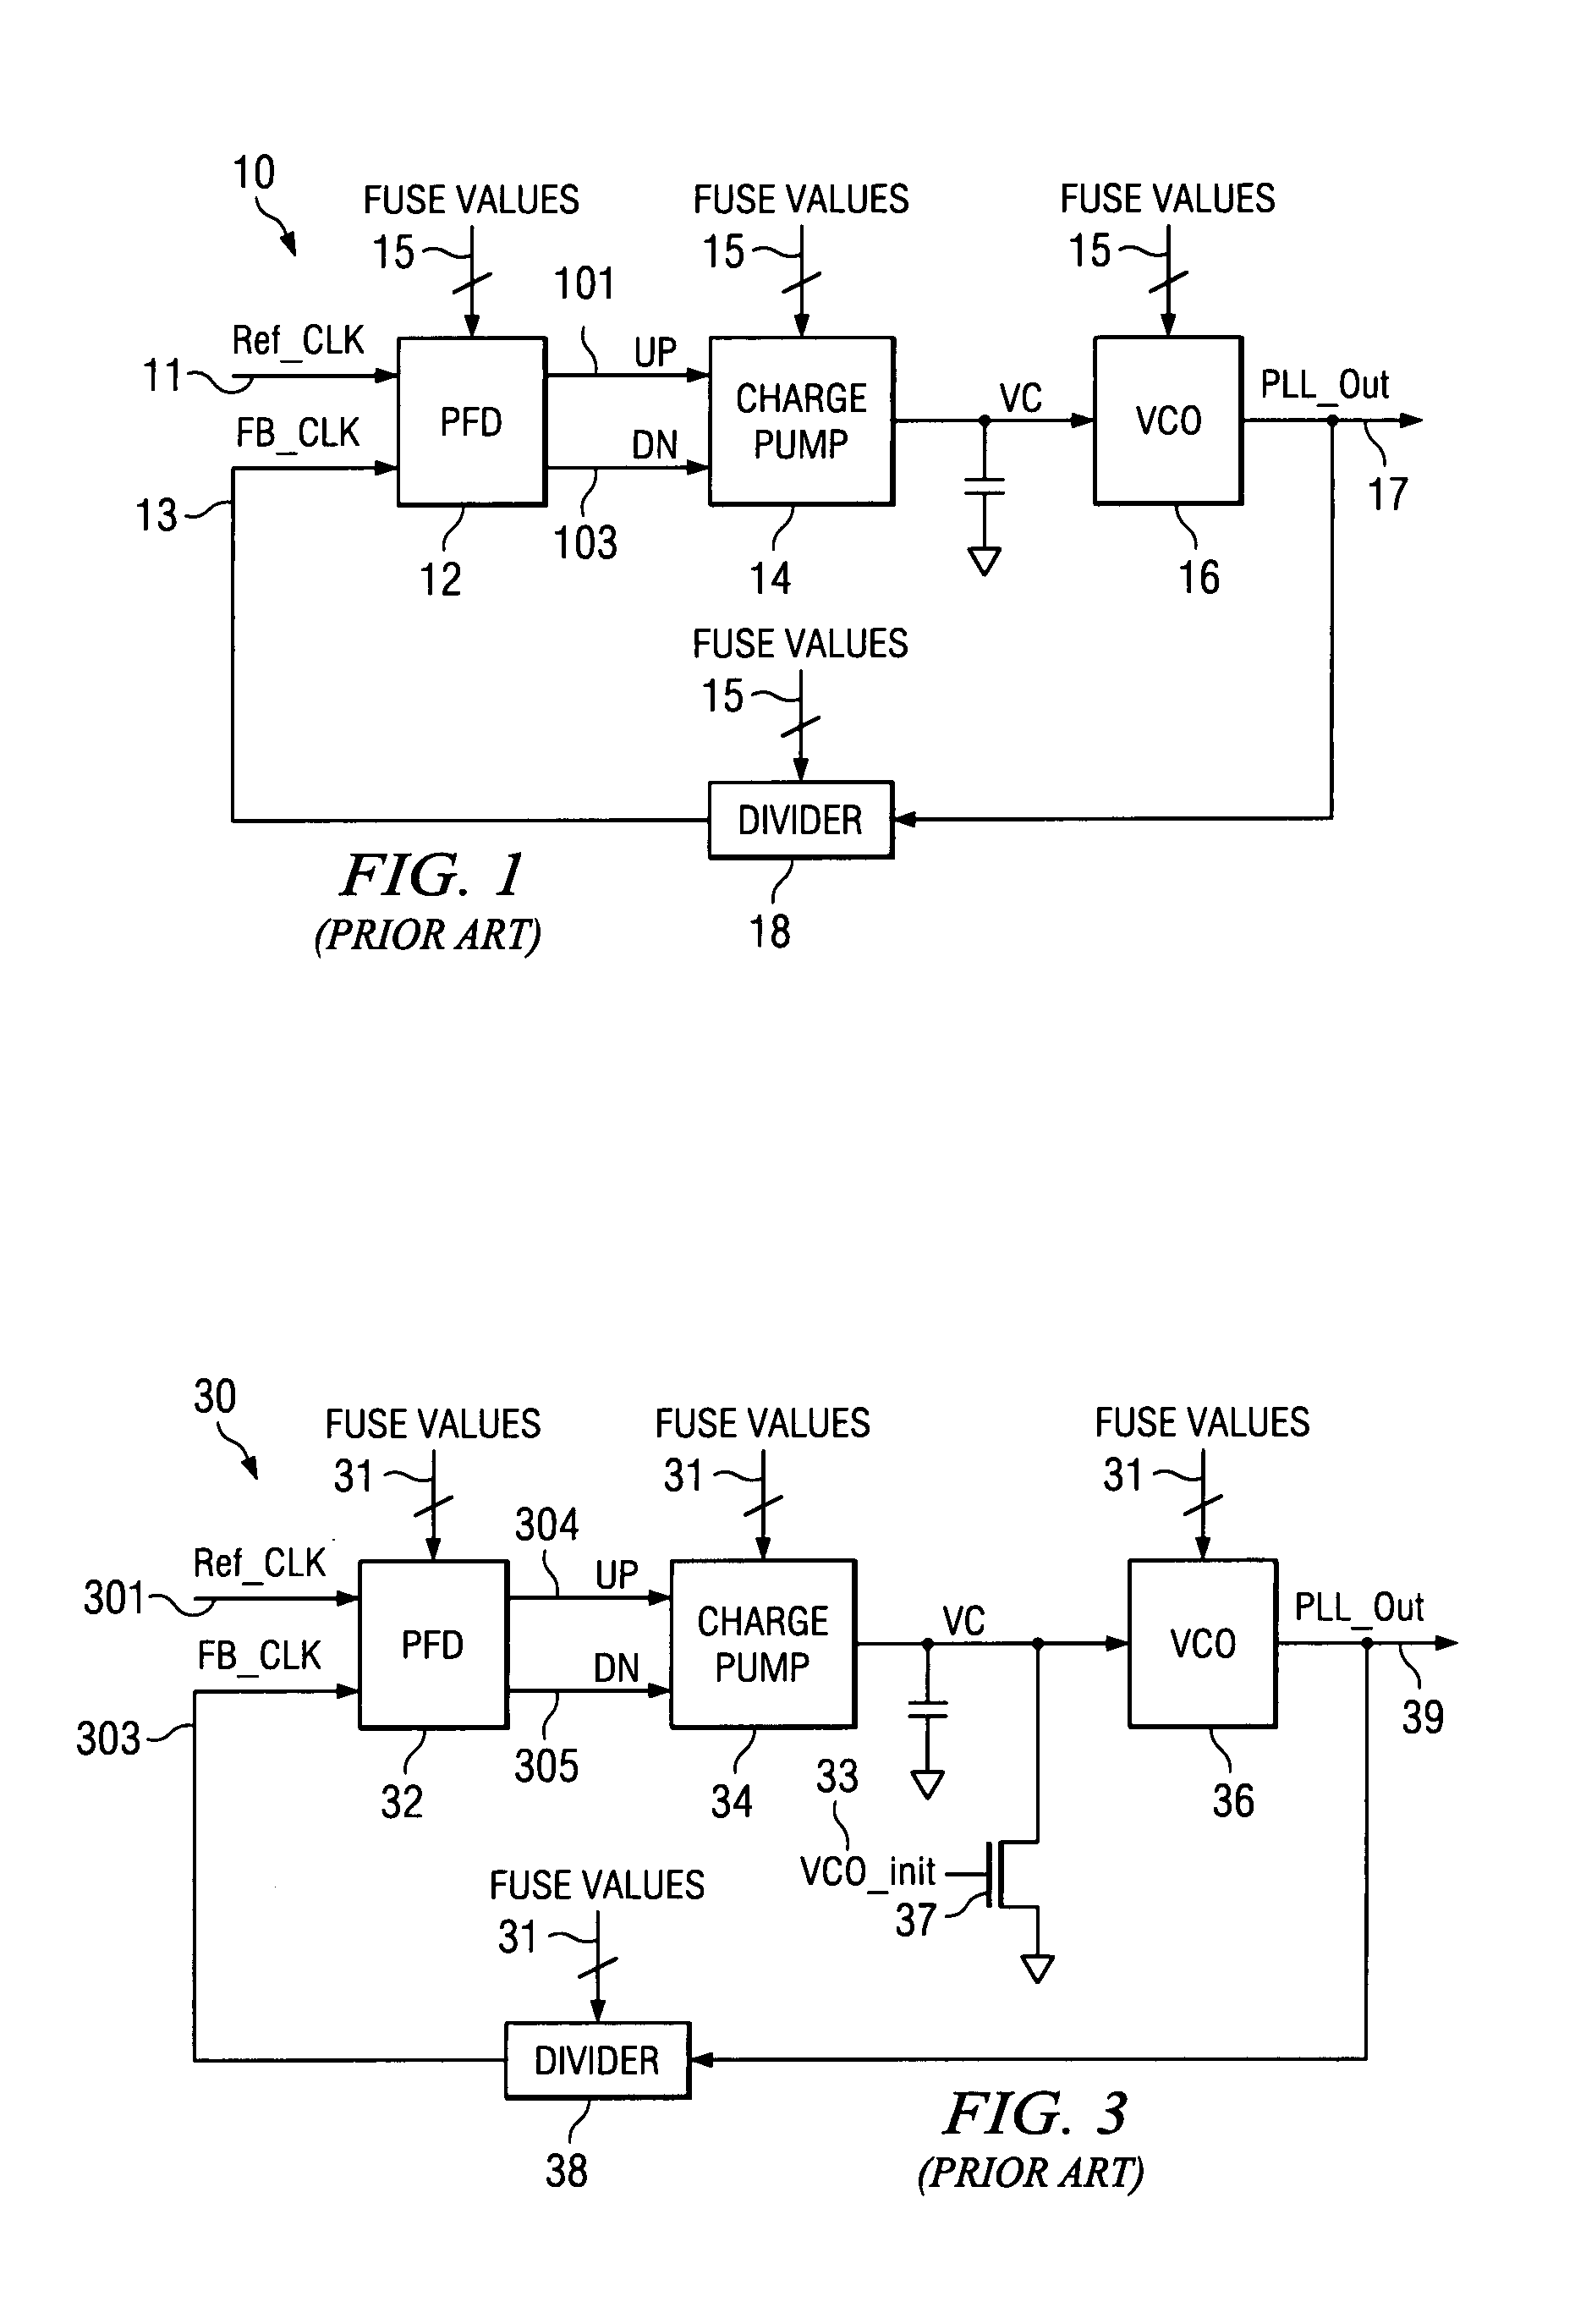
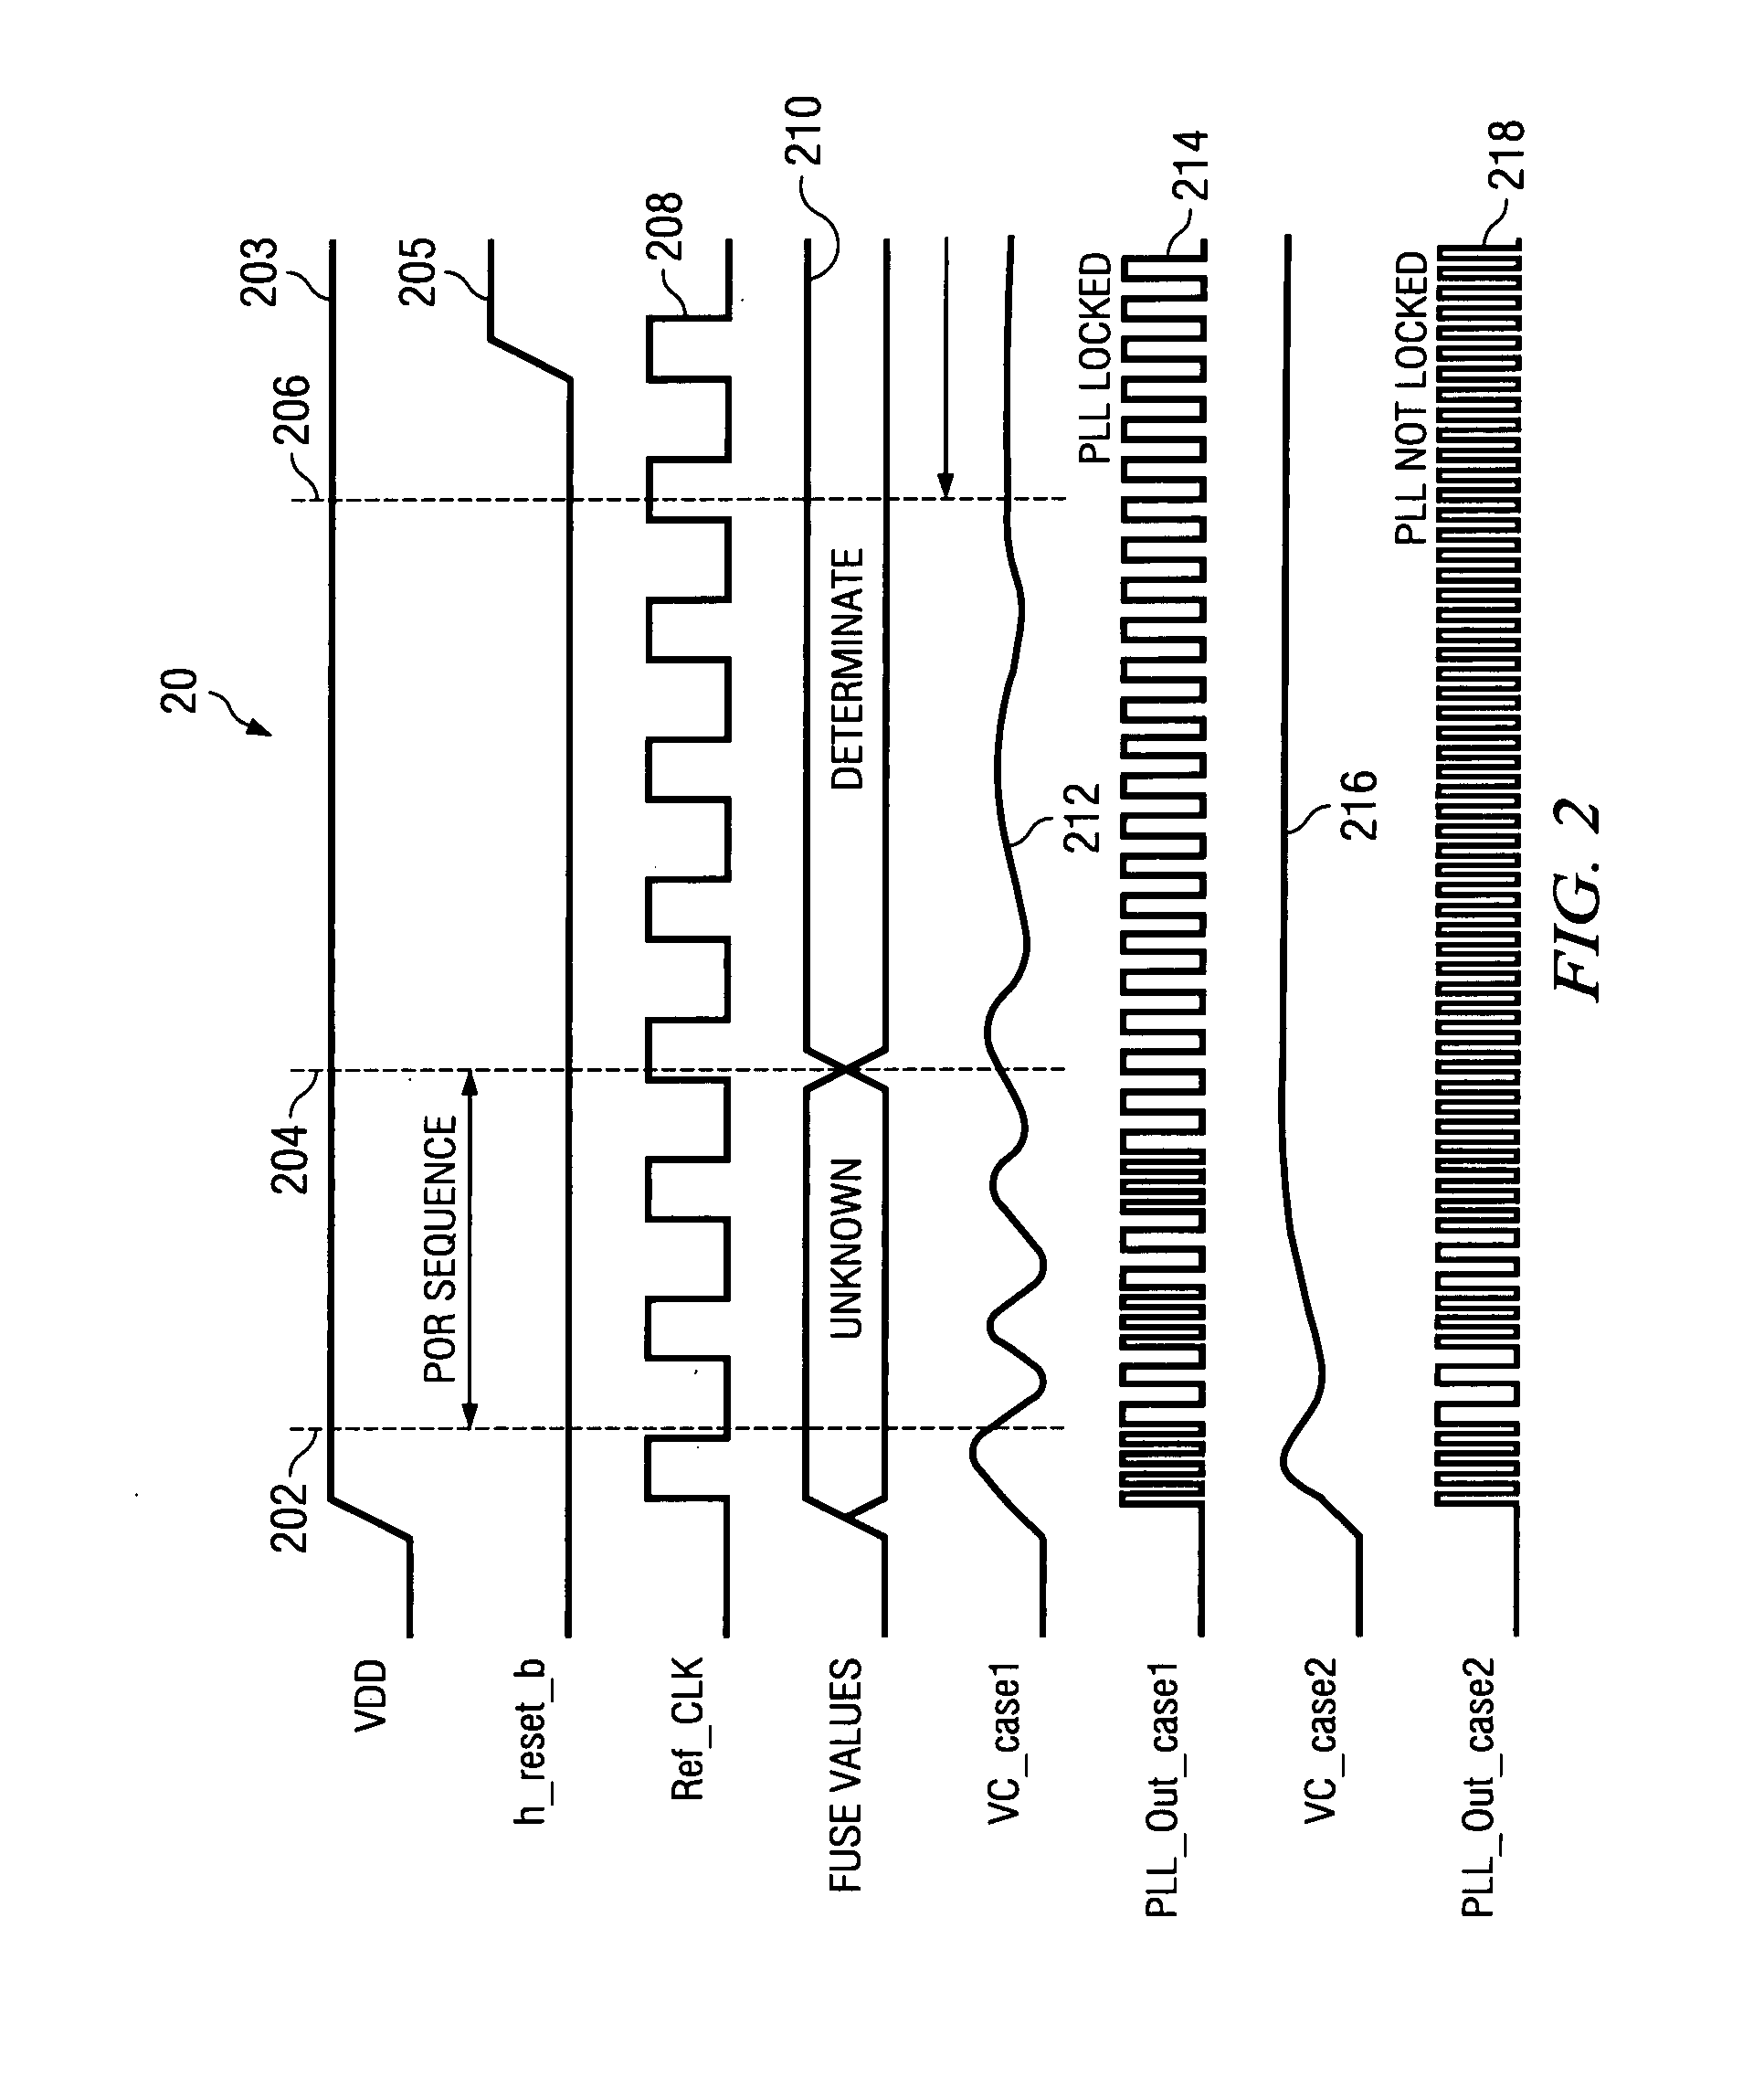
Devices, methods, and systems for initializing a phased-lock loop (PLL) circuit which prevents or reduces the occurrences of voltage-controlled oscillator (VCO) frequency exceeding a divider's maximum input frequency, thus preventing or reducing at least one cause of lock failure. Disclosed is a PLL circuit having logic circuitry configured to hold a PFD reference-signal input low and provide a divided reference-signal to a PFD feedback-signal input while an initialization signal is asserted. The PLL can be initialized without adding circuitry to a VCO input. By asserting an initialization signal, an input voltage to a voltage-controlled oscillator is attenuated. The initialization signal is adapted to gate inputs to and outputs from the phase-locked loop circuit.
Owner:KK TOSHIBA
Imaging device and digital camera using the imaging device
InactiveUS20040062535A1Solve the thickerLow costTelevision system detailsColor television detailsCamera lensOptical power
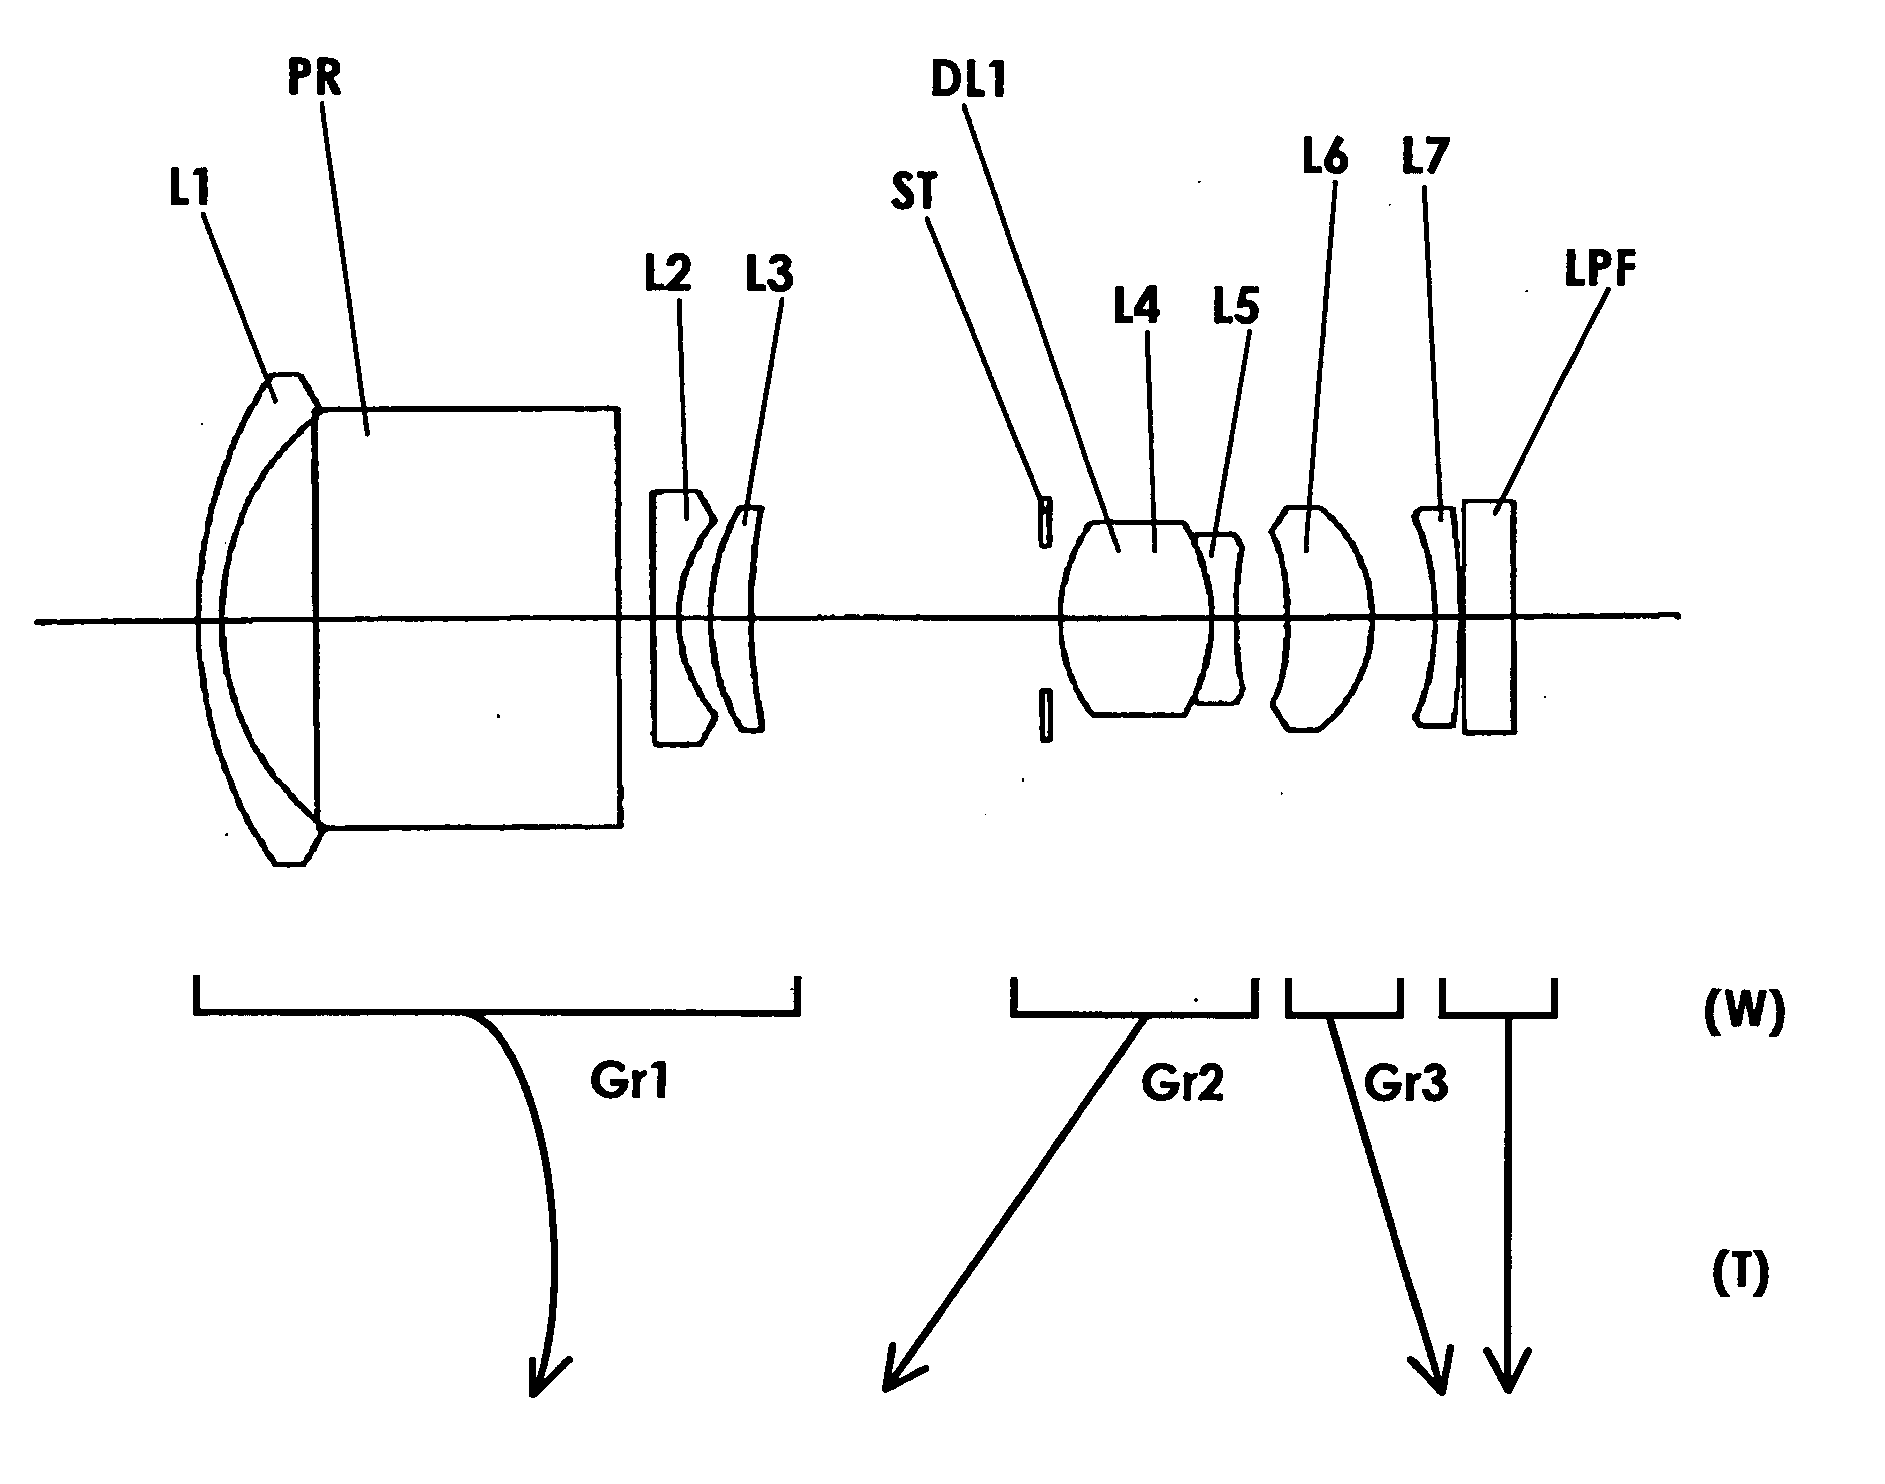
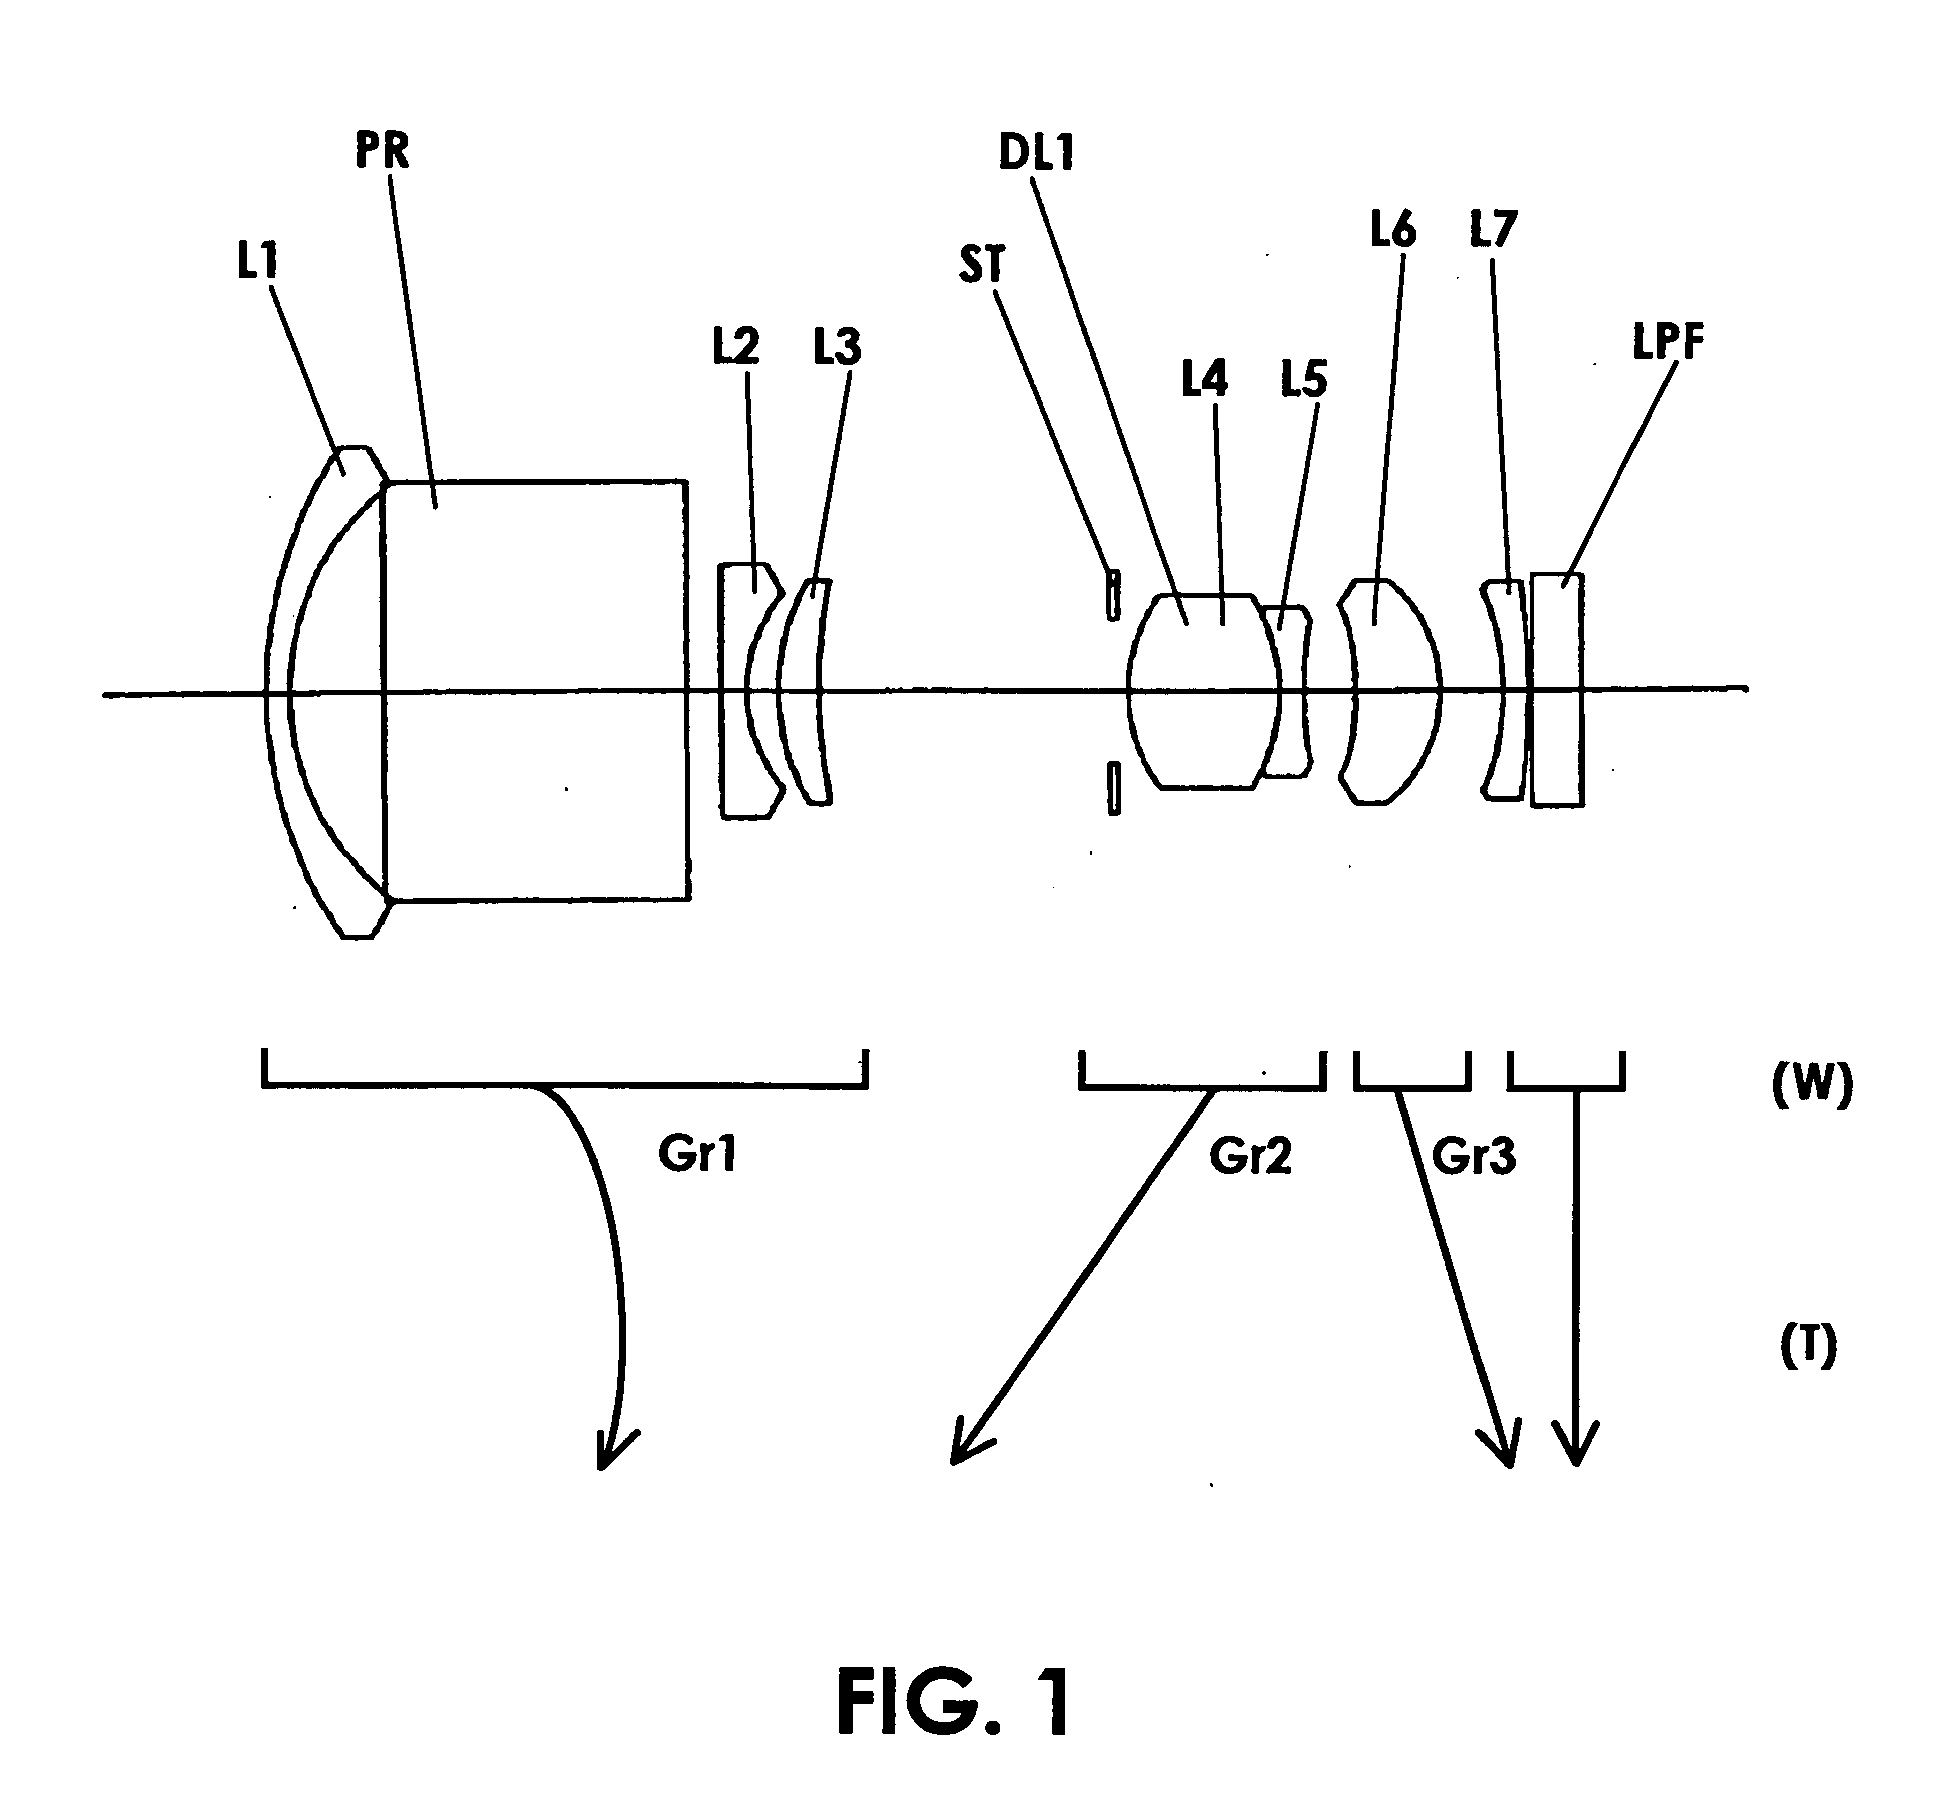
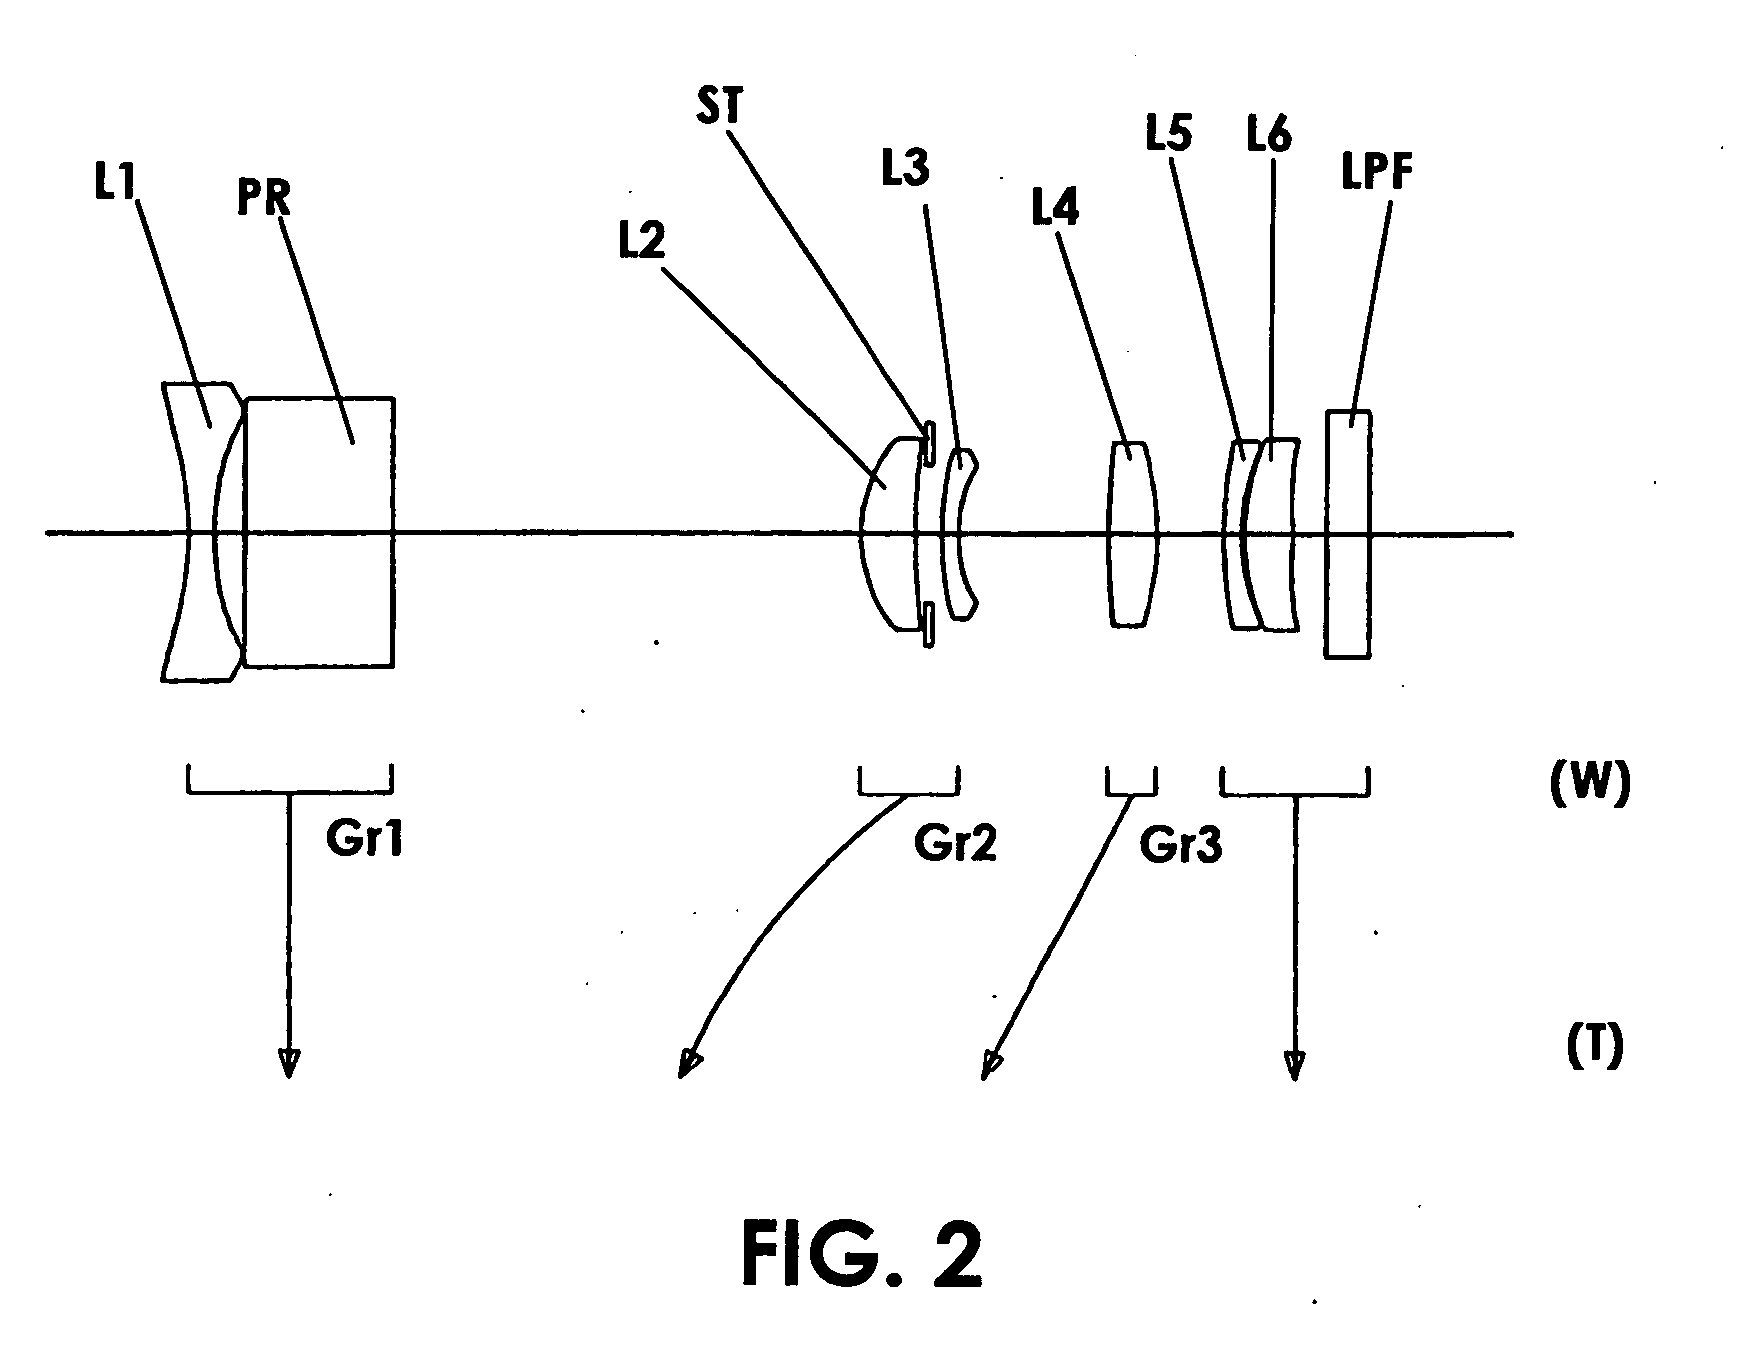
An imaging device has a zoom lens system having a plurality of lens units and forming an optical image of an object so as to continuously optically zoom by varying distances between the lens unit; and an image sensor converting the optical image formed by the zoom lens system to an electric signal. The zoom lens system comprises, from an object side a first lens unit being overall negative and including a reflecting surface that bends a luminous flux substantially 90 degrees; and a second lens unit disposed with a variable air distance from the first lens unit, and having a negative optical power.
Owner:MINOLTA CO LTD
Point-line feature fusion-based transformer substation inspection robot positioning and mapping method
ActiveCN119444849Afast extractionGuaranteed accuracyImage analysisInformation technology support systemPattern recognitionGyroscope
The invention discloses a transformer substation inspection robot positioning and mapping method based on point-line feature fusion. According to the method, a binocular camera is used for collecting point-line features in an image frame, and high-quality long-line features are quickly obtained based on an adaptive criterion optimized EDLines algorithm; the spatial depth of point-line features is obtained through triangularization of a binocular camera, and redundant line features are filtered based on a length response threshold strategy of the spatial depth of a transformer substation. Based on a point-line pole feature pole plane constraint method, IMU information and visual information are combined, gyroscope zero offset is independently estimated and optimized, IMU pre-integration information is updated, and a more accurate initial posture of the inspection robot is obtained. A point-line feature dictionary based on a transformer substation scene and a large-scale equipment target detection model in a transformer substation are made, closed-loop detection is performed through transformer substation equipment road signs and point-line features, and rapid relocation correction is performed on sliding windows of a current key frame and a previous fixed key frame number. And finally, the pose of the substation inspection robot and a substation scene map are optimized through global BA, and the problem of large-scale scene error drift accumulation is solved.

Owner:HANGZHOU DIANZI UNIV