

Patents
Literature
50results about How to "Improve precision control ability" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Coriolis mass flowmeter amplitude self-adaptation control method based on fluid state detecting
InactiveCN104792379AFluid state predictionAvoid vibration stopMechanical oscillations controlDirect mass flowmetersUltrasound attenuationStable state
The invention discloses a Coriolis mass flowmeter amplitude self-adaptation control method based on fluid state detecting. An ultrasonic transducer is arranged at an inlet end of a Coriolis mass flowmeter detecting pipe, through the attenuation effect on ultrasonic signals from impurities such as air bubbles, whether the amplitude value of received signals is changed suddenly is detected and judged via a threshold value comparer, whether impurities exist at a fluid state is obtained, and then switching of fixed PID and fuzzy PID amplitude controllers is carried out. According to the method, by detecting on the fluid state and self-adaptation controller switching, high-precision stable state control performance can be kept, system dynamic response speed can be improved, measuring pipe vibration stopping is avoided, stable vibration is reestablished quickly, the self adaptability of Coriolis mass flowmeter measuring pipe amplitude control is enhanced, and the reliability and the metering performance of a Coriolis mass flowmeter under a complex working condition are improved.


Owner:ZHEJIANG UNIV
Power demand side response strategy optimization method based on feedback information extraction
ActiveCN119627911AImprove precision control abilityImprove stabilityLoad forecast in ac networkForecastingPower usageElectric power
The invention discloses a power demand side response strategy optimization method based on feedback information extraction, and relates to the technical field of energy management, and the method comprises the steps: calling a line architecture of a target region, obtaining a user set on a power transmission line, and collecting the power use data of users. And carrying out power and power consumption period disassembly analysis on the data to obtain a power concentration interval, a power consumption peak period and a power consumption valley period of the user. And formulating an initial power demand side response strategy. And collecting feedback information of the user through the feedback window. And in combination with the power interval and the response coefficient of the user, optimizing the initial strategy to form a final power demand side response strategy. The technical problem that an existing power demand side response strategy lacks dynamic adaptability to actual power consumption behaviors and response conditions of users is solved, and the technical effects that the accurate regulation and control capacity of power loads is improved, the influence of power peak and valley fluctuation on a power grid is reduced, and therefore the stability of the power grid is enhanced are achieved.

Owner:JIANGSU ELECTRIC POWER INFORMATION TECH
Rolling method of hot rolling strip steel narrow interval width control
ActiveCN104259219ASolve the problem of no suitable installation locationSolve the big problem of not being able to transfer dataMetal rolling stand detailsRoll mill control devicesSufficient timeMathematical model
A rolling method of hot rolling strip steel narrow interval width control belongs to the technical field of steel rolling and machining. A slab width gauge is additionally arranged in a feed roller channel of a heating furnace, so that slab width values measured by the slab width gauge can be transferred to a rough rolling pre-computation model in sufficient time. Meanwhile, the problem of unavailability of data transfer between a CCID model of a heating furnace model and a Siemens model of a rough rolling width pre-computation model is solved, and exact slab width values are transferred to the rough rolling pre-computation model to ensure the accurate data calculation. According to the rolling method of hot rolling strip steel narrow interval width control, a slab thermometer is used for converting slab cold state width to be transferred to a hot rolling steel strip control mathematical model, the actually measured slab width is used for replacing the planed slab width, so that the deviation of a calculated value to an actual value of a width model vertical roll rolling force, the ability to control the accuracy of the width model is enhanced, the calculation accuracy of the width model is greatly improved, accordingly width unplanned products are greatly reduced, and annual estimated profit can be 3.85 million yuan.
Owner:HEBEI IRON AND STEEL
Rehabilitation manipulator based on high-order adaptive learning control
ActiveCN110394806AAdaptiveImprove versatilityProgramme-controlled manipulatorGripping headsFinger jointSelf adaptive
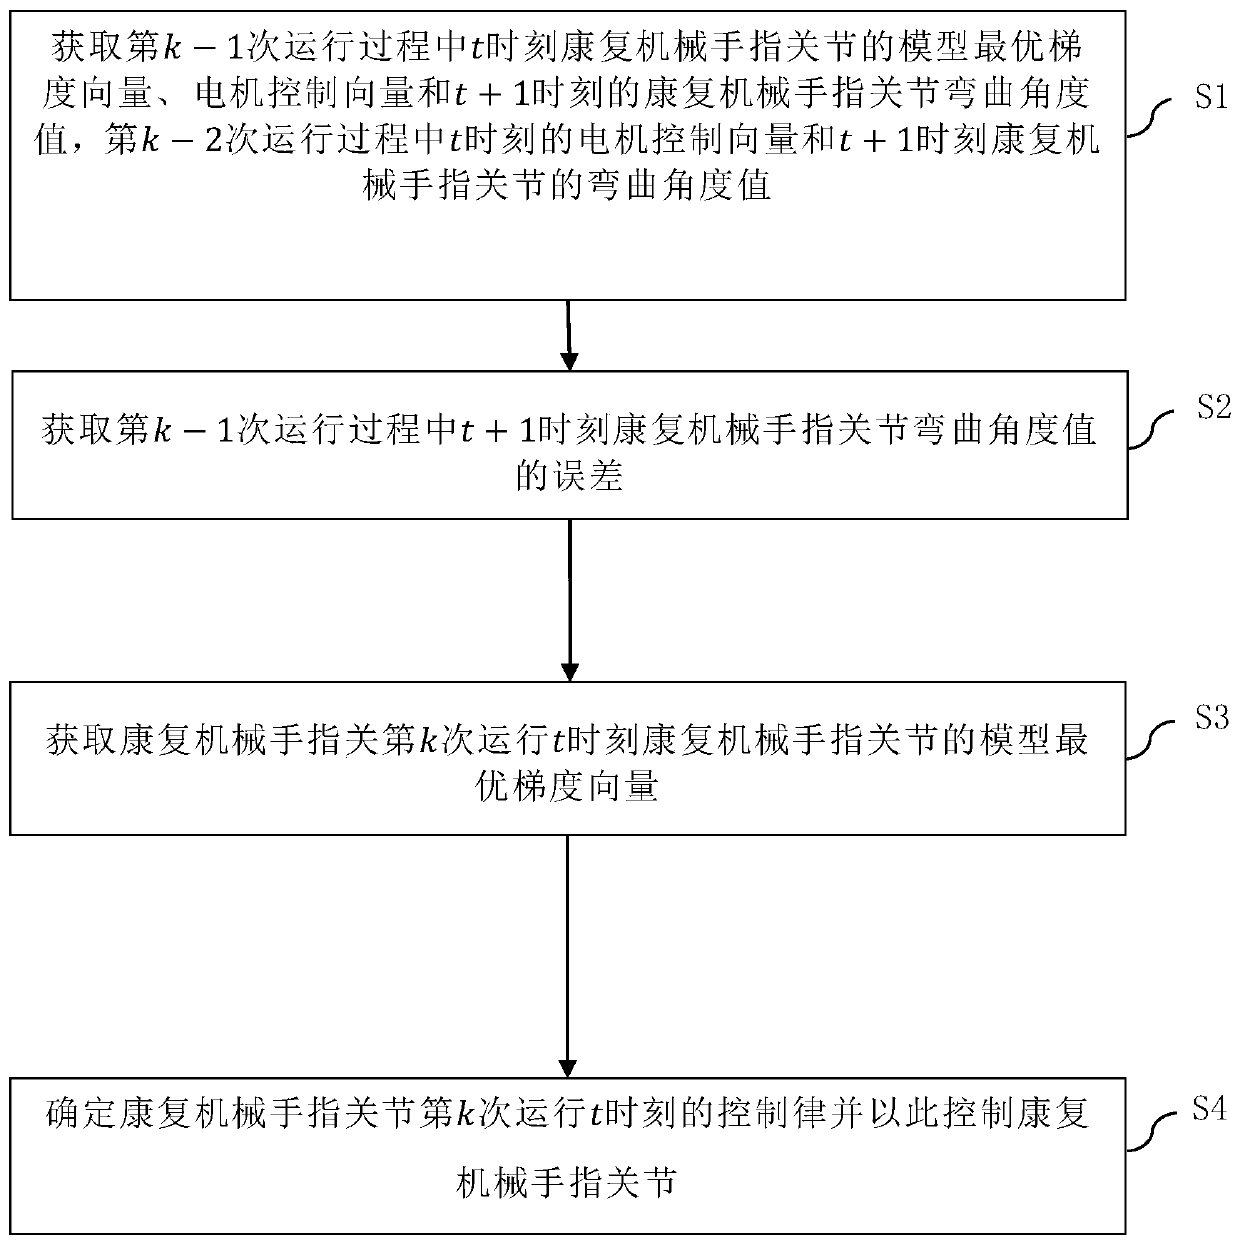
The invention discloses a rehabilitation manipulator based on high-order adaptive learning control. The rehabilitation manipulator comprises a plurality of rehabilitation mechanical finger joints anda processor; and the processor comprises a first acquisition module, a second acquisition module, a third acquisition module and a control module. According to the technical scheme, the rehabilitationmanipulator can be used for completing tracking tasks on respective expected tracks after a certain number of times of learning, the control problem is solved, and the control precision is high.

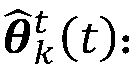
Owner:BEIHANG UNIV
Motor control method and device, equipment terminal and readable storage medium
ActiveCN110768607AImprove precision control abilityLow costElectric motor controlControl engineeringElectric machinery
The invention relates to a motor control method and device, an equipment terminal and a readable storage medium. The motor control method comprises the following steps: acquiring actual rotation angleoutput data of a motor in a preset angle range; performing function regression on the actual rotation angle output data according to preset expected response data to determine a global calibration function; and according to the global calibration function, carrying out global calibration processing in a nonlinear dynamic inverse mode on a motor input signal. A high-precision motor control effectcan be realized under the condition that a motor servo system is not replaced, and the transformation cost of a common AGV is reduced.


Owner:SANY HEAVY IND CO LTD (CN)
Diffusion process for reducing doping concentration of N + region of solar cell
ActiveCN114678449AReduce doping concentrationImprove work efficiencySemiconductor/solid-state device testing/measurementFinal product manufacturePhysical chemistrySolar battery
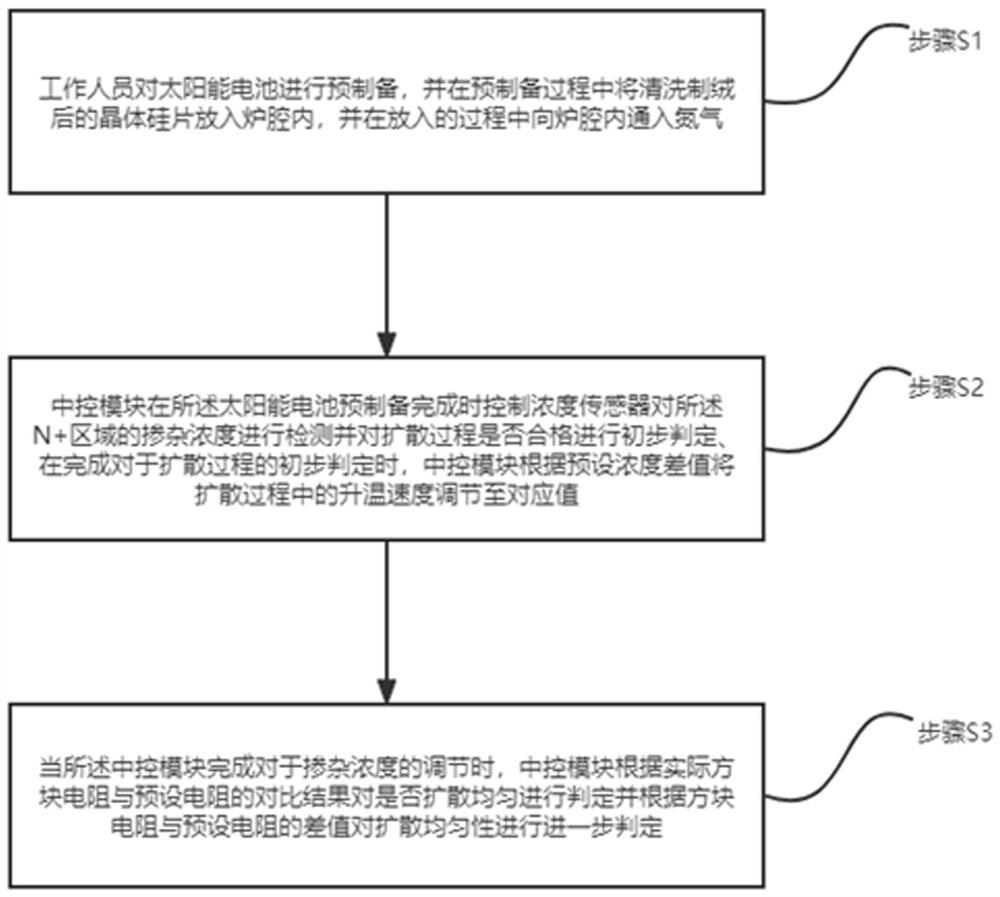
The invention relates to the technical field of solar cells, in particular to a diffusion process for reducing the doping concentration of an N + region of a solar cell, which comprises the following steps of: S1, prefabricating the solar cell by a worker, and putting a cleaned and textured crystal silicon wafer into a furnace chamber in the prefabrication process; s2, a central control module controls a concentration sensor to detect the doping concentration of the N + region and preliminarily judge whether the diffusion process is qualified or not when preparation of the solar cell is completed, and the temperature rise speed in the diffusion process is adjusted to a corresponding value according to a preset concentration difference value; and S3, when the central control module completes adjustment of the doping concentration, the central control module judges whether diffusion is uniform or not according to a comparison result of the actual square resistance and the preset resistance and further judges the diffusion uniformity according to a difference value of the square resistance and the preset resistance. According to the invention, the doping concentration in the diffusion process is reduced, and the diffusion uniformity is accurately controlled.
Owner:一道新能源科技股份有限公司
Method and system for optimizing production of animal blood protein powder
ActiveCN119623880AFull Coverage Guaranteedmake up for limitationsAnalysing fluids using sonic/ultrasonic/infrasonic wavesResourcesPROTEIN S HEERLENAcoustic energy
The invention discloses a production optimization method and system for animal blood-made protein powder, particularly relates to the technical field of production monitoring, and aims to solve the problem that the existing method is difficult to effectively identify the potential hidden danger of the cavitation effect caused by ultrasonic waves in the production process of the animal blood-made protein powder. The method comprises the following steps: capturing harmonic characteristics of ultrasonic signals, and identifying an acoustic energy dense region in combination with a spectrum analysis algorithm; constructing a turbulence disturbance intensity graph model, and analyzing the distribution characteristic change of the dissolved gas in combination with a graph embedding learning algorithm; determining a cavitation potential risk area based on the identified first and second potential risk areas; in the cavitation potential risk area, the comprehensive influence of the bubble group synergistic effect and the heat effect is evaluated by analyzing the complexity of bubble interaction energy distribution and the diffusion degree of local high temperature; and finally, determining a cavitation hidden danger caused by ultrasonic waves by calculating a cavitation influence coefficient, and optimizing production process parameters according to a determination result.

Owner:GUIZHOU JIANYI MEASUREMENT TECH CO LTD +1
Geometric feature-based aero-engine blade milling location degree prediction method
ActiveCN119416387AImprove generalization abilityImprove forecast accuracyGeometric CADSustainable transportationPattern recognitionData set
The method for predicting the milling position degree of the aero-engine blade based on the geometrical characteristics comprises the steps that key machining parameters are determined, and current data in the machining process are collected; importing the blade model into CAD software, parameterizing the curved surface of the blade, establishing a UV coordinate system, uniformly arranging detection points, detecting the location degree of each detection point, and calculating the curvature of each detection point along a V-direction streamline through the CAD software; calculating the residual height h of each detection point, and forming a data set by the current data corresponding to different key processing parameters, the curvature of the detection point along the V-direction streamline, the residual height of the detection point and the location degree of the corresponding detection point; constructing a neural network model; and training a neural network model by using the data set to predict the milling position degree of the aero-engine blade. According to the method, the complex nonlinear relation can be learned from the processing data, and the generalization ability and the prediction precision of the model can be improved through the geometric features.

Owner:HEBEI UNIV OF TECH +1
Motor and application
ActiveCN119420109AImprove electromagnetic compatibilityImprove stabilityAssociation with control/drive circuitsElectric motor controlControl signalElectric machine
The invention provides a motor and application, and the motor comprises a first housing which is provided with a main control circuit board; the second shell is positioned in the first shell and is provided with a driving circuit board and a motor body; wherein the driving circuit board is electrically connected with the main control circuit board and the motor body, the main control circuit board is used for outputting a control signal to the driving circuit board, and the driving circuit board is used for outputting a driving signal to the motor body based on the received control signal; wherein the driving circuit board is located at the end of the motor body, the driving circuit board is provided with two opposite surfaces, one surface is provided with a driving circuit, the other surface is provided with a sensing element, and the driving circuit is electrically connected with a main control circuit of the main control circuit board and the motor body. The sensing element is used for detecting the position of the motor body and outputting a detection signal to the driving circuit. The stability and reliability of the motor are improved.

Owner:深圳宇凡微电子有限公司
Internal booster pump of low-temperature natural gas cylinder for vehicle
PendingCN110185598AImprove gasification efficiencyImprove combustion efficiencyPump testingPositive displacement pump componentsHigh densityGas cylinder
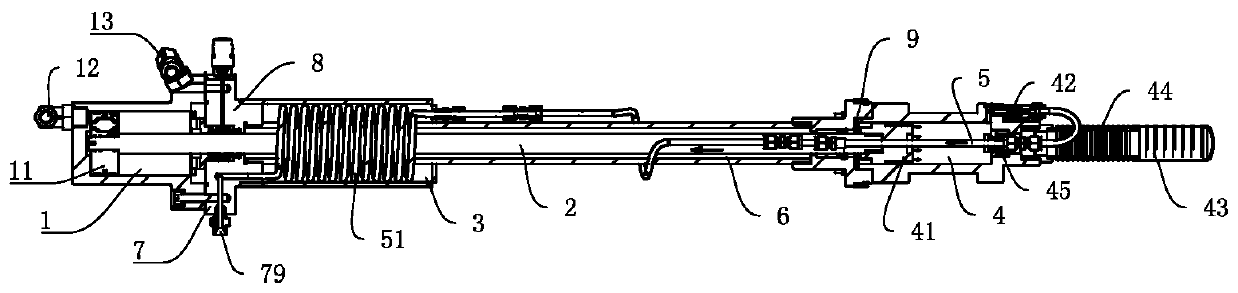
The invention discloses an internal booster pump of a low-temperature natural gas cylinder for a vehicle, and relates to the technical field of natural gas cylinders. The internal booster pump comprises a hydraulic oil cylinder, a cooling liquid cavity, a balance cavity, a compression cylinder, a piston rod and a filter. The internal booster pump can replace an external gasifier and a booster of aconventional vehicle-mounted LNG gas cylinder. A vehicle-mounted hydraulic system is used for supplying power to drive the internal booster pump to work, the booster pump is provided with a gasification device to exhaust LNG in the low-temperature gas cylinder and to gasify and pressurize the LNG to 34.5 Mpa, and the high-pressure and high-density form of natural gas is kept stable and reliable.
Owner:山东奥扬新能源科技股份有限公司
Curved surface numerical control machining information extraction method and device based on B-spline curved surface reconstruction
The invention relates to the technical field of numerical control system information processing, in particular to a curved surface numerical control machining information extraction method and device based on B-spline curved surface refactor.The method comprises the steps that after three-dimensional space position information of a curved surface machining cutter location point is obtained, cutter location point parameterization is carried out to determine B-spline curved surface parameters of a cutter positioning curved surface; determining a precision index according to the sum of squares of deviations of all cutter location points and the cutter positioning curved surface to calculate a regression matrix, determining a fairing energy index to calculate a fairing energy matrix, combining the two indexes to determine a comprehensive index, generating a curved surface reconstruction problem, solving the problem to obtain a reconstruction structure, and extracting curved surface numerical control machining information. Therefore, the problem that in the related technology, when a curved surface reconstruction algorithm processes disordered spatial discrete cutter location points, the requirements for rapidity, fairness and precision are generally difficult to consider is solved.

Owner:TSINGHUA UNIVERSITY +1
Welding equipment for oil film bearing bush production
ActiveCN119238006AHigh precisionImprove controllabilityWelding/cutting auxillary devicesAuxillary welding devicesMechanical engineeringWelding process
The invention discloses welding equipment for oil film bearing bush production, which comprises a welding frame, an adjusting mechanism is arranged on the welding frame, a bearing frame is rotatably connected to the welding frame, a rotating mechanism is cooperatively connected to the bearing frame, a plurality of guide rods are arranged and are respectively mounted on a lifting frame, and the lifting frame is provided with a lifting mechanism. The design of the adjusting mechanism ingeniously solves the problem of accurate positioning in the oil film bearing bush welding process, the welding precision and efficiency are remarkably improved, coarse adjustment of the position between the bush body and the connecting disc is achieved through the cooperation of the bearing frame and the lifting frame and the combination of the adjusting capacity of the differential bolt, vertical movement of the lifting frame is ensured through the arrangement of the guide rod, and the welding quality is improved. The adjusting accuracy is guaranteed, the combined design of the fixing sleeve, the push rod and the push disc provides stable and reliable support for the sleeve body, and the design of the internal rod and the friction plate is matched with the precise matching of the threaded block and the transverse rod, so that the precise adjustment of a small distance is realized.

Owner:JIANGSU TAIQUN PRECISION CNC EQUIP CO LTD
Design method of permanent magnet synchronous motor position controller based on active disturbance rejection
PendingCN119298736AReduce use lossquick responseElectric motor controlCAD circuit designPermanent magnet synchronous motorControl engineering
The invention provides a design method of an active-disturbance-rejection permanent magnet synchronous motor position controller. The design method comprises the steps of hardware circuit design and active-disturbance-rejection controller module design. The hardware circuit design comprises an alternating current power supply module, a rectifier bridge circuit module, an inverter circuit module, a permanent magnet synchronous motor module, a voltage sampling module and a current sampling module. The design steps of the active-disturbance-rejection controller module are as follows: S1, designing a current loop PI active-disturbance-rejection controller; S2, designing a rotating speed loop PI active-disturbance-rejection controller; compared with a traditional control method, the active-disturbance-rejection permanent magnet synchronous motor position controller provided by the invention has stronger disturbance rejection, rapid dynamic response, high-precision control capability and better system robustness, and can be widely applied to industrial scenes with high performance requirements.

Owner:JIANGSU YINONE ELECTRIC
Infrared transmitting tube control circuit and method
PendingCN111179574AReduce the number of repeated operations of the infrared remote controlExtended service lifeNon-electrical signal transmission systemsRemote controlEngineering
The invention relates to the technical field of infrared remote control, in particular to an infrared transmitting tube control circuit and method. The device comprises at least two infrared transmitting tube units; the control end of the controller is respectively connected with the at least two infrared transmitting tube units; wherein the controller controls the at least two infrared transmitting tube units at the same time through the control end. The control end of the controller is connected with at least two infrared transmitting tube units; according to the infrared remote controller,the transmitting angle of the infrared transmitting tube and the plurality of infrared transmitting tube units are utilized, so that the transmitting angle of the infrared remote controller can be enlarged by adding the infrared transmitting tube, the control range of the infrared remote controller is enlarged, the repeated operation frequency of a user is reduced, and the user can operate controlled equipment conveniently.


Owner:珠海荣邦智能科技有限公司
A rehabilitation manipulator based on high-order adaptive learning control
ActiveCN110394806BAdaptableImprove versatilityProgramme-controlled manipulatorGripping headsPhysical medicine and rehabilitationControl engineering
The invention discloses a rehabilitation manipulator based on high-order adaptive learning control. The rehabilitation manipulator comprises a plurality of rehabilitation mechanical finger joints anda processor; and the processor comprises a first acquisition module, a second acquisition module, a third acquisition module and a control module. According to the technical scheme, the rehabilitationmanipulator can be used for completing tracking tasks on respective expected tracks after a certain number of times of learning, the control problem is solved, and the control precision is high.


Owner:BEIHANG UNIV
Multi-aperture imaging-based space remote sensing target positioning optical system and calibration method
ActiveCN121187009BHigh coincidencereduce random errorTesting optical propertiesOptical elementsHigh resolution imagingOptical instrumentation
The application relates to a multi-aperture imaging space remote sensing target positioning optical system and a calibration method, and relates to the field of remote sensing and aerospace imaging optical instruments. The application solves the contradiction between the requirements of a large field of view and high resolution imaging of a traditional single-aperture optical imaging system, and realizes accurate positioning of a target to meet the intelligent requirements of a multi-aperture optical imaging system. The multi-aperture imaging space remote sensing target positioning sub-aperture imaging optical system comprises an electromagnetic vibration mirror, a beam-reducing telescope group, a fast reflection mirror and a rear focusing mirror group. The beam-reducing telescope group and the rear focusing mirror group are connected through the fast reflection mirror, and the light beam is connected with an imaging branch through the electromagnetic vibration mirror. After the imaging light beam passes through the telescope system, the imaging light beam is reflected by the fast reflection mirror and focused on a detector to form an image. The application is also suitable for a mobile platform for fast positioning and high-precision capturing of a dynamic target in the field of industrial precision machining and space remote sensing.

Owner:CHANGCHUN UNIV OF SCI & TECH
A Control System of Equivalent Sampling Ground Penetrating Radar with Variable Gain Based on cpld
ActiveCN109655927BPrecisely control signal emissionControl signal emissionDetection using electromagnetic wavesControl systemGround-penetrating radar
The invention belongs to the field of ground penetrating radars, and discloses a variable gain equivalent sampling ground penetrating radar control system based on a CPLD. The system comprises an upper computer, an MCU microprocessor, a CPLD, a delay trigger circuit, an analog-to-digital conversion module, a transmitting module and a receiving module, wherein the upper computer is used for sendingan instruction and receiving a signal; the MCU microprocessor is used for realizing information interaction between an upper computer and the CPLD, the analog-to-digital conversion module is used forconverting the received electromagnetic wave signal of the receiving module into a digital signal, the CPLD is used for setting the total number of times of transmitting and receiving the electromagnetic wave signals, the transmitting time interval, the receiving time interval and the gain multiplying power; the delay trigger circuit is used for controlling whether the transmitting module and thereceiving module transmit or receive signals; and the receiving module is used for realizing equivalent gain sampling. According to the invention, surface deep weak signals are acquired, and the parallel processing capability and the detection precision of the control system are improved.


Owner:HUAZHONG UNIV OF SCI & TECH
A welding device for producing oil film bearing bushings
ActiveCN119238006BHigh precisionImprove controllabilityWelding/cutting auxillary devicesAuxillary welding devices
The present invention discloses a welding device for producing oil film bearing bushings, comprising a welding frame, wherein an adjusting mechanism is arranged on the welding frame, the receiving frame is rotatably connected to the welding frame, the rotating mechanism is cooperatively connected to the receiving frame, a plurality of guide rods are arranged, and the plurality of guide rods are respectively mounted on the lifting frame, the design of the adjusting mechanism cleverly solves the problem of precise positioning in the welding process of the oil film bearing bushings, and significantly improves the welding accuracy and efficiency, and through the cooperation of the receiving frame and the lifting frame, combined with the adjustment ability of the differential bolt, the coarse adjustment of the position between the sleeve body and the connecting plate is realized, the setting of the guide rod ensures the vertical movement of the lifting frame, and ensures the accuracy of the adjustment, the combined design of the fixed sleeve, the push rod and the push plate provides stable and reliable support for the sleeve body, and the design of the internal rod and the friction plate, combined with the precise cooperation of the threaded block and the transverse rod, realizes the precise adjustment of the small distance.

Owner:JIANGSU TAIQUN PRECISION CNC EQUIP CO LTD
Copper foil additive control system capable of controlling and feeding back additive dropping dosage
InactiveCN119411191AImprove precision control abilityeasy to controlElectroforming processesControl systemControl engineering
The invention discloses a copper foil additive control system capable of controlling and feeding back additive dropping dosage, which relates to the technical field of copper foil production and comprises an additive storage module, a metering pump, a controller, a liquid drop monitoring unit, a feedback unit and a filtering unit, the additive storage module consists of a stirring device and a heating device; the metering pump is electrically and interactively connected with the additive storage module; the controller comprises a data processing module, an instruction generation module and a storage module; the liquid drop monitoring unit is used for monitoring parameters of the output additive liquid drops in real time and transmitting data to the feedback unit; the feedback unit is composed of a sensor assembly and a data transmission line. The system is applied to a copper foil production additive control system, plays a role in monitoring and feedback, realizes an effect of accurately controlling the dosage of an additive, and is beneficial to refinement of copper foil production; full-automatic monitoring can be achieved, manual testing is not needed, manual intervention is reduced, manual testing errors are reduced, the production cost is reduced, and abnormal risks are reduced.

Owner:南京龙鑫电子科技有限公司
Optimization method of spacecraft small-angle attitude maneuver control parameters
ActiveCN102411304BImprove design efficiencyImprove precision control abilityAdaptive controlSpacecraft attitude controlFlywheel
The invention relates to an optimization method of spacecraft small-angle attitude maneuver control parameters. The method comprises the following steps of: under a spacecraft attitude reference coordinate system, establishing spacecraft dynamic and kinematic models containing flywheels or control moment gyros; based on a non-linear input limited feedback control method, designing a small-angle attitude maneuver controller; and selecting the optimized control parameters of the designed attitude controller by using an improved simulated annealing optimization method. The method provided by the invention can be suitable for the design of various spacecraft attitude controllers. The method provided by the invention, which belongs to the technical field of aerospace control, not only can improve the spacecraft attitude control accuracy but also can greatly improve the controller design efficiency.


Owner:BEIHANG UNIV
A precision control method and system for flavoring and adding materials
ActiveCN111067130BImprove stabilityImprove precision control abilityTobacco preparationRatio controlProcess engineeringFood science

Owner:CHINA TOBACCO HENAN IND
Arbor dropper irrigation device
ActiveCN222170734UImprove precision control abilityGuaranteed longevityWatering devicesCultivating equipmentsAgricultural scienceElectrical battery
The utility model discloses a dropper irrigation device for arbor. The dropper irrigation device comprises a protective shell, a main water pipe connector, a water outlet hose, a photovoltaic panel, a dripping head, a charging socket, a rectangular concave window, a sealing cover, a sealing side belt, a PCB, a controller, a storage battery, a wireless communication module and an electromagnetic valve. The drip irrigation control system is reasonable in design, a user uses configured communication equipment to be connected with the wireless communication modules distributed at the drip heads to give instructions to the controller, the controller controls the electromagnetic valves to be started and stopped, the accuracy control performance of drip irrigation is enhanced, and the drip irrigation control system is suitable for popularization and application. The problem that starting and stopping of dripping are difficult to control due to the fact that dripping heads are many is solved, excessive irrigation water consumption is reduced, water resources can be further saved, the mode of photovoltaic power generation and charging power storage is adopted, the durability of power output and power supply of a power source can be guaranteed, the specification is light, dismounting and mounting are convenient, and long-term cyclic use can be achieved.

Owner:JIANGSU AIJING CONSTR CO LTD
Rocket recovery trajectory optimization method with optimal terminal time estimation
PendingCN114117631AEstimated speedExcellent unimodal propertiesGeometric CADSystems for re-entry to earthClassical mechanicsRocket
The invention discloses a rocket recovery trajectory optimization method with optimal terminal time estimation, which comprises the following steps of: firstly, demonstrating a rocket sublevel acceleration change trend based on an optimal control theory, and further giving an analysis form of a terminal acceleration upper bound by utilizing terminal state constraint; meanwhile, in consideration of the flight state of a rocket sublevel landing section, the thrust adjusting capacity of an engine, the mass flow of a spray pipe and other limiting conditions, the acceleration change rate relative to the speed change rate (acceleration) in the vertical landing process is small, and the maximum acceleration is selected as a lower bound judgment index. Finally, according to the continuous change characteristic of the rocket sub-level acceleration, a terminal acceleration estimation formula in an n-order polynomial form is introduced, and the upper bound and the lower bound of the optimal terminal time are given by comparing the terminal acceleration estimation value in the polynomial form with the upper bound of the terminal acceleration; according to the method, the optimal terminal time can be quickly estimated, the convergence performance is good, the precision and the calculation efficiency are high, and the potential of online application is achieved.


Owner:BEIJING INSTITUTE OF TECHNOLOGYGY
Flexible material hoist position robust controller and design method thereof
InactiveCN108363300AOptimized Control ModeHigh control precisionAdaptive controlDynamic modelsHarmonic
The invention belongs to the technical field of mechanical control, and discloses a design method of a position robust controller of a flexible material hoist with chain transmission and harmonic geartransmission. The method comprises the steps that an inertial coordinate system of the flexible material hoist is established; based on the inertial coordinate system, the flexible material hoist issimplified into a two-degree-of-freedom flexible joint manipulator model with chain transmission and harmonic gear transmission; a dynamic model of the flexible joint manipulator model is established;a singular perturbation method is used to reduce the dynamic model into a fast variable subsystem and a slow variable subsystem; and a hybrid controller is formed based on the fast variable subsystemand the slow variable subsystem to control the flexible transmission joint material hoist. According to the controller and the design method thereof, the flexible vibration of the flexible material hoist can be reduced, and the control precision is improved.


Owner:WUHAN UNIV OF SCI & TECH
Method and system for controlling plasma scalpel by utilizing EMC (Electro Magnetic Compatibility) rectification filtering technology
PendingCN119210176Astable jobimprove performanceAc-dc conversion without reversalDc-dc conversionConvertersCapacitance
The invention relates to the field of electromagnetic compatibility, and discloses a method and a system for controlling a plasma scalpel by utilizing an EMC (Electro Magnetic Compatibility) rectifying and filtering technology, and the method comprises the following steps: determining a target voltage demand required by the plasma scalpel; analyzing the electromagnetic interference state of the plasma knife, and constructing an EMC filter of the plasma knife; the method comprises the following steps of: constructing a rectifying circuit for filtering alternating current voltage; calculating a filtering capacitance value and a filtering inductance value which are required for eliminating a pulse component; constructing a filtering circuit of the rectifying circuit; determining a boosting coefficient of a to-be-constructed converter corresponding to a plasma knife, determining a switching frequency and a duty ratio of the to-be-constructed converter, and calculating a conversion inductance value of the to-be-constructed converter; constructing a DC-DC converter of the converter to be constructed; and a control system of the plasma knife is constructed, and precise control over the plasma knife is executed. The precise control effect of the plasma knife can be improved.

Owner:XINHUA SURGICAL INSTR CO LTD
A motor and its application
ActiveCN119420109BImprove electromagnetic compatibilityImprove stabilityAssociation with control/drive circuitsElectric motor control
The present application provides a motor and application, the motor comprising: a first housing, provided with a main control circuit board; a second housing, located inside the first housing, provided with a driving circuit board and a motor body; wherein the driving circuit board is electrically connected to the main control circuit board and the motor body respectively, the main control circuit board is used to output a control signal to the driving circuit board, and the driving circuit board is used to output a driving signal to the motor body based on the received control signal; wherein the driving circuit board is located at the end of the motor body, the driving circuit board has two opposite surfaces, one of which is provided with a driving circuit and the other is provided with a sensing element, the driving circuit is electrically connected to the main control circuit of the main control circuit board and the motor body respectively, and the sensing element is used to detect the position of the motor body and output a detection signal to the driving circuit. The present application improves the stability and reliability of the motor.

Owner:深圳宇凡微电子有限公司
Parallel robot mechanical arm and control method thereof
PendingCN113843778AImprove accuracyImprove precision controlProgramme-controlled manipulatorMechanical engineeringRoboty
The invention discloses a parallel robot mechanical arm and a control method thereof. The parallel robot mechanical arm comprises a static platform, a driving arm, a driven arm and a movable platform, the driving arm is mounted outside the static platform, a servo motor is arranged inside the static platform and connected with the driving arm through an output shaft, the exterior of the driving arm is connected with a tripod through a rotating shaft, and the other end of the tripod is connected with the driven arm through the rotating shaft. According to the parallel robot mechanical arm and the control method thereof, the integrated sensor is additionally arranged on the movable platform, the problem that the control of a traditional parallel robot mechanical arm is not accurate enough in a complex environment is solved, the parallel robot mechanical arm can detect different functions through four sensors in the working process, the control accuracy of the mechanical arm by a parallel robot can be improved, and according to the control method, the precise control effect of the parallel robot in the complex environment is greatly improved, the overall structure is compact, and the practicability is high.


Owner:CHENGDU TECHCAL UNIV
Multi-mode high-power hydraulic driving system based on hybrid power and control method
ActiveCN111731263AQuick engagementFast separationHybrid vehiclesGas pressure propulsion mountingPower batteryElectric machinery
The invention belongs to the technical field of mechanical-electrical-hydraulic hybrid power and hydraulic driving, and particularly relates to a multi-mode high-power hydraulic driving system based on hybrid power and a control method. The hydraulic driving system comprises a main power system, an auxiliary power system and a central control unit. The main power system comprises an engine, a motor, a hydraulic pump, a main hydraulic oil way, a clutch, a brake locking mechanism, a fixed-speed-ratio transmission case, a motor controller, a high-voltage direct-current bus, a power battery, a brake resistor and the like and is used for achieving the high-power hydraulic load driving function. The auxiliary power system comprises a low-power motor, a motor controller, a fixed-speed-ratio transmission case, a brake locking mechanism, a hydraulic pump, an auxiliary hydraulic oil way, a one-way valve and the like and is used for accurately controlling the stroke at the tail end of the hydraulic stroke. The control method provided by the invention is integrated in the central control unit and is used for realizing coordination control on the working mode and the working process of the hydraulic driving system.


Owner:CHINA NORTH VEHICLE RES INST
Rehabilitation robot based on adaptive learning control
InactiveCN110339016AImprove versatilityWide range of applicationsProgramme-controlled manipulatorJointsSelf adaptiveManipulator
The invention discloses a rehabilitation robot based on adaptive learning control, which comprises a plurality of rehabilitation mechanical finger joints, further comprises a processor, wherein the processor comprises a first acquisition module, a second acquisition module, a third acquisition module and a control module. Through the technical solution of the invention, the rehabilitation robot completes the tracking task for the respective desired trajectories after a certain number of running times, solves the control problem, and has high control precision.

Owner:BEIHANG UNIV
A winter environment simulation detection device
ActiveCN115493862Bincrease authenticityavoid wastingStructural/machines measurementCalorimeterThermodynamicsProcess engineering
The present invention relates to the technical field of heat storage systems, and in particular to a winter environment simulation detection device, comprising: a refrigerator, a cold capacity transmission pipeline module, a cold water tank, a first cold and heat exchange pipeline module, a water-to-water plate heat exchanger, a second cold and heat exchange pipeline module, a hot water tank, a heat exchange pipeline module, and an electric heat storage device, wherein the cold capacity transmission pipeline module is used to transmit the cold capacity generated by the refrigerator to the cold water tank connected to the first energy transmission pipeline module; the first cold and heat exchange pipeline module is used to increase the return water temperature of the cold water tank by cold and heat exchange; the second cold and heat exchange pipeline module is used to increase the water temperature of the water-to-water plate heat exchanger by cold and heat exchange; and the heat exchange pipeline module is used to heat the water in the hot water tank by heat exchange. The present invention realizes accurate monitoring of the working condition of the electric heat storage device and improves the heating efficiency of the electric heat storage device in winter.

Owner:HEBEI UNIV OF TECH