
Patents
Literature
59 results about "Parallel genetic algorithm" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Network text segmenting method based on genetic algorithm
ActiveCN101710333AImprove Segmentation AccuracyGenetic modelsSpecial data processing applicationsDeep levelGlobal optimal
The invention discloses a network text segmenting method based on the genetic algorithm, used for segmenting short network texts. The method comprises the following steps of: evaluating a Latent Dirichlet allocation (LDA) model corresponding to a corpus by using a Gibbs sampling method, inferring latent topic information using the model, representing texts by using the latent topic information; then transforming a text-segmenting process into a multi-target optimum process by using a parallel genetic algorithm, and calculating the coherency of segmented units, the divergence among the segmented units and fitness functions by using deeper semantic information; and carrying out the genetic iteration of the text segmenting process, and determining whether the segmenting process terminates based on the similarity among multi-iteration results or the upper limit of iterations to obtain the global optimal solution for segmenting the texts. Therefore, the invention improves the accuracy for segmenting the short network texts.


Owner:NANTONG LONGXIANG ELECTRICAL APPLIANCE EQUIP +1
Distribution method of container quay berths and shore bridges
InactiveCN101789093AGlobal optimization is beneficialReduce loading and unloading energy consumptionForecastingDistribution methodPerformance index
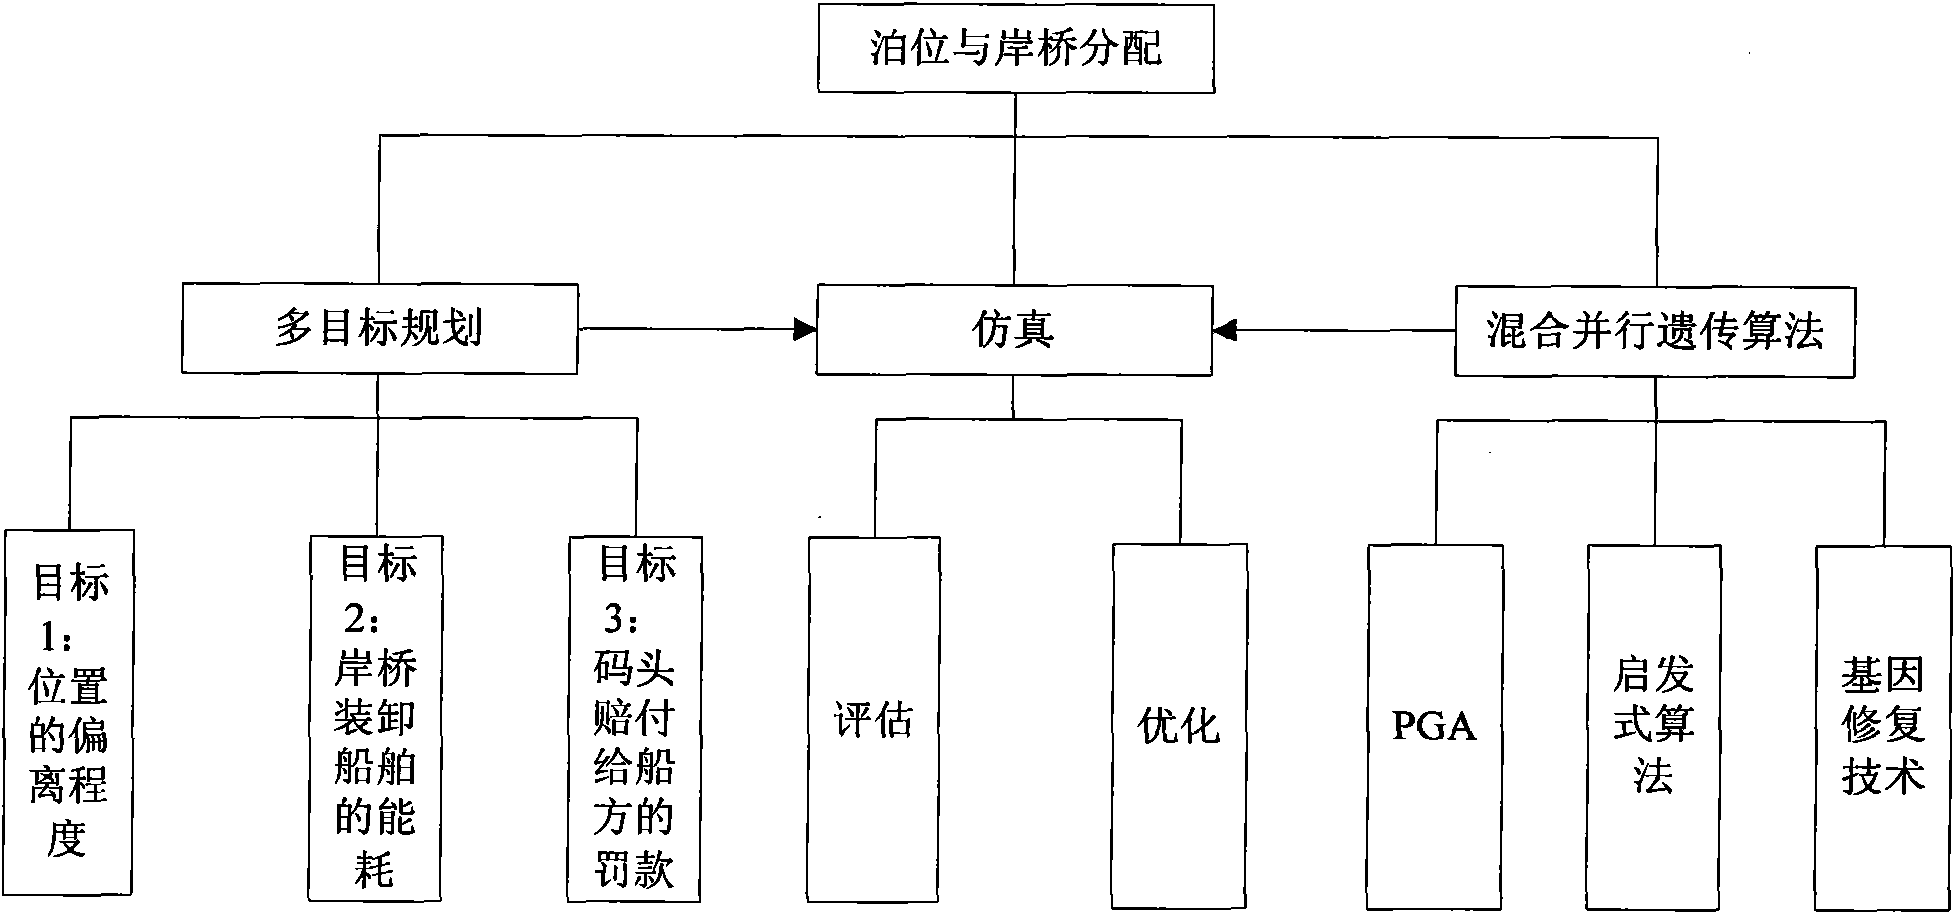
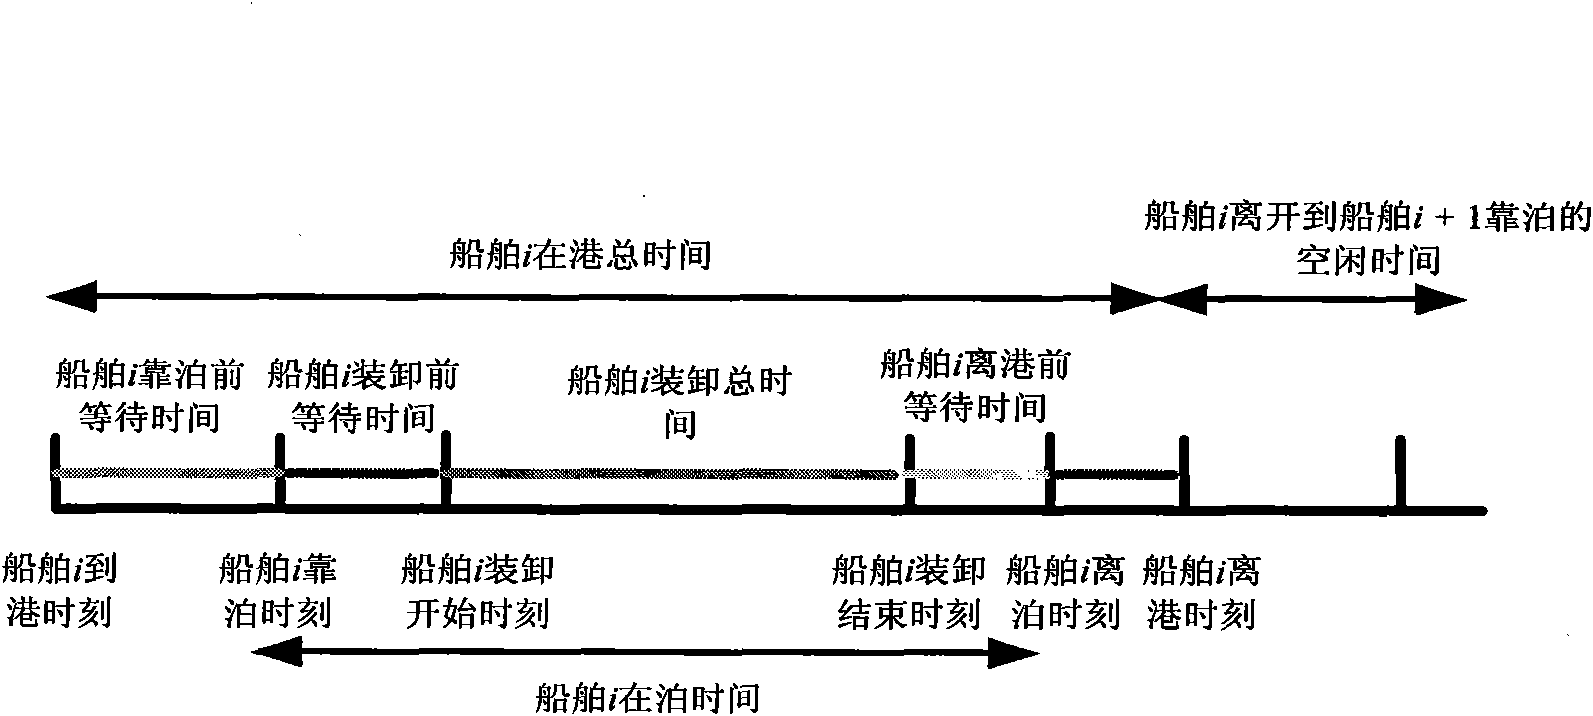
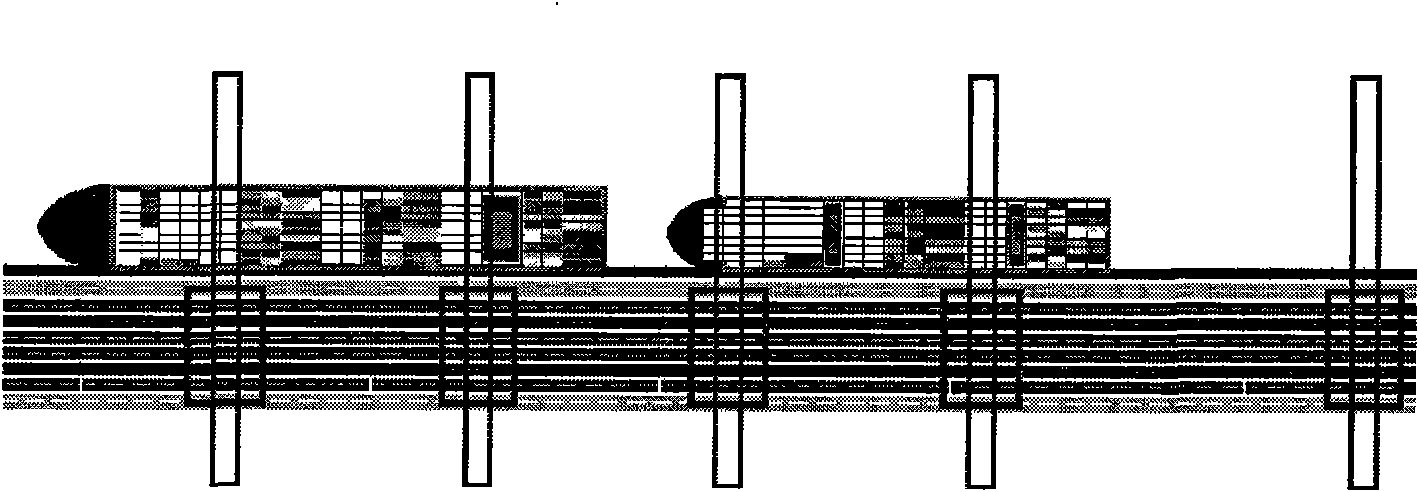
The invention provides a distribution method of container quay berths and shore bridges. By adopting a rolling type plan distribution method, berth and shore bridge distribution models based on multi-objective planning are constructed; the models are based on a continuous quay wall line and are more closer to the actual berth conditions of a quay; a hybrid algorithm on the basis of combining a heuristic algorithm and a parallel genetic algorithm is adopted, and the performance of the hybrid algorithm is evaluated by a distribution simulation system of the container quay berths and the shore bridges; when a berth and shore bridge distribution scheme is generated, the simulation system simulates the distribution scheme, acquires corresponding performance indexes, compares with other schemes, and determines whether the scheme is better; and a method combining simulation and a gene repair technology is adopted to repair infeasible schemes, thereby being favorable for reducing the time in port of a ship, and reducing the horizontal transport distance when the ship is loaded or unloaded, the energy consumption of the shore bridges, and the fine that the quay pays to a ship owner, and further reducing the loading and unloading cost on the quay, improving the service quality of the quay and realizing the purpose of the invention.
Owner:SHANGHAI MARITIME UNIVERSITY
Genetic algorithm optimization-based software test data generation method
ActiveCN108509335AFast convergenceSave time and costSoftware testing/debuggingArtificial lifeAlgorithmTest data generation
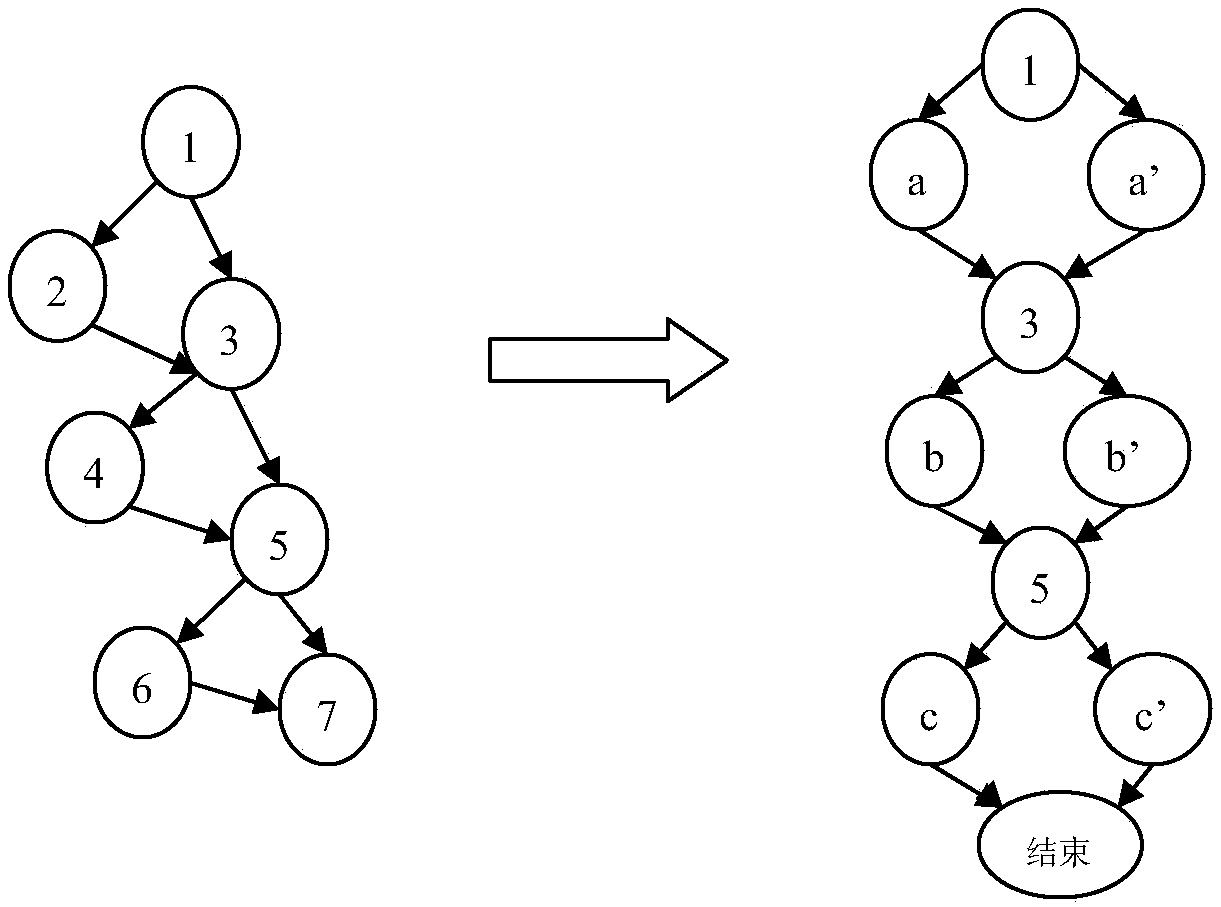
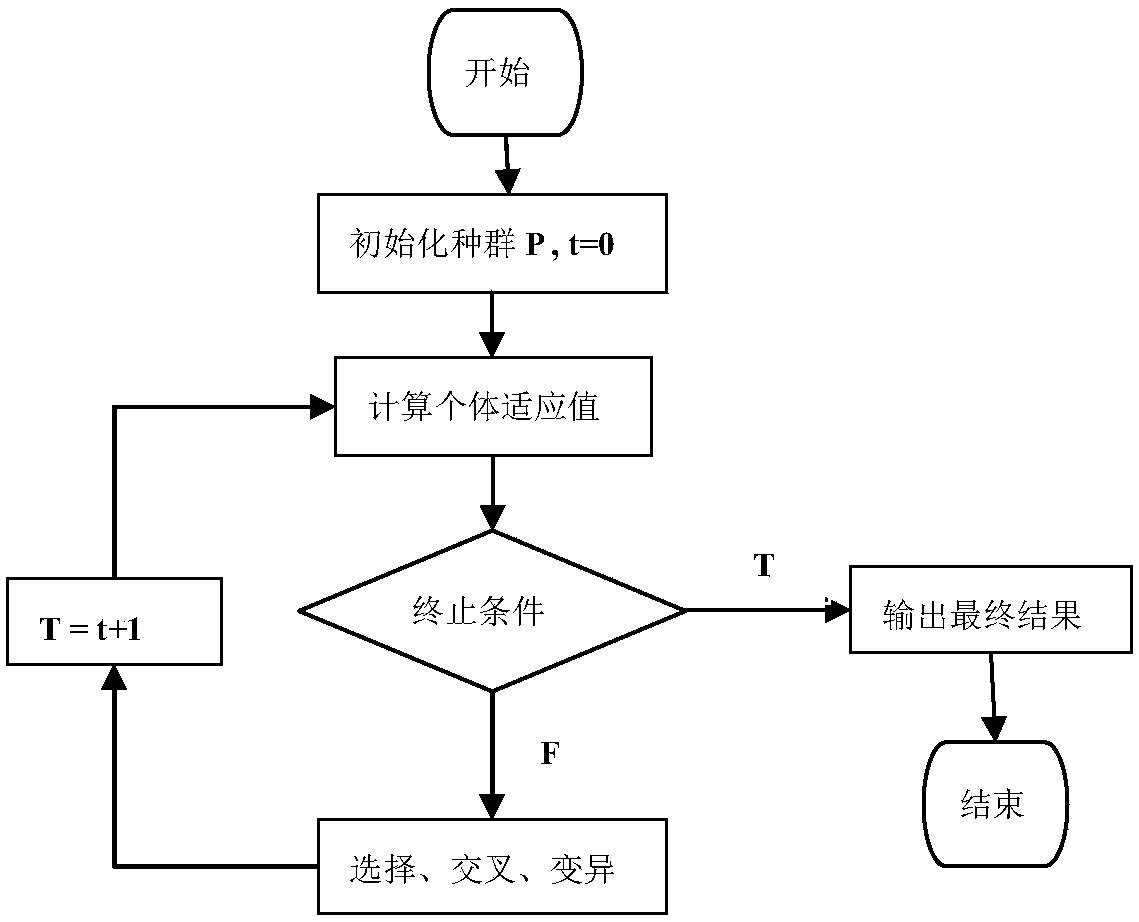
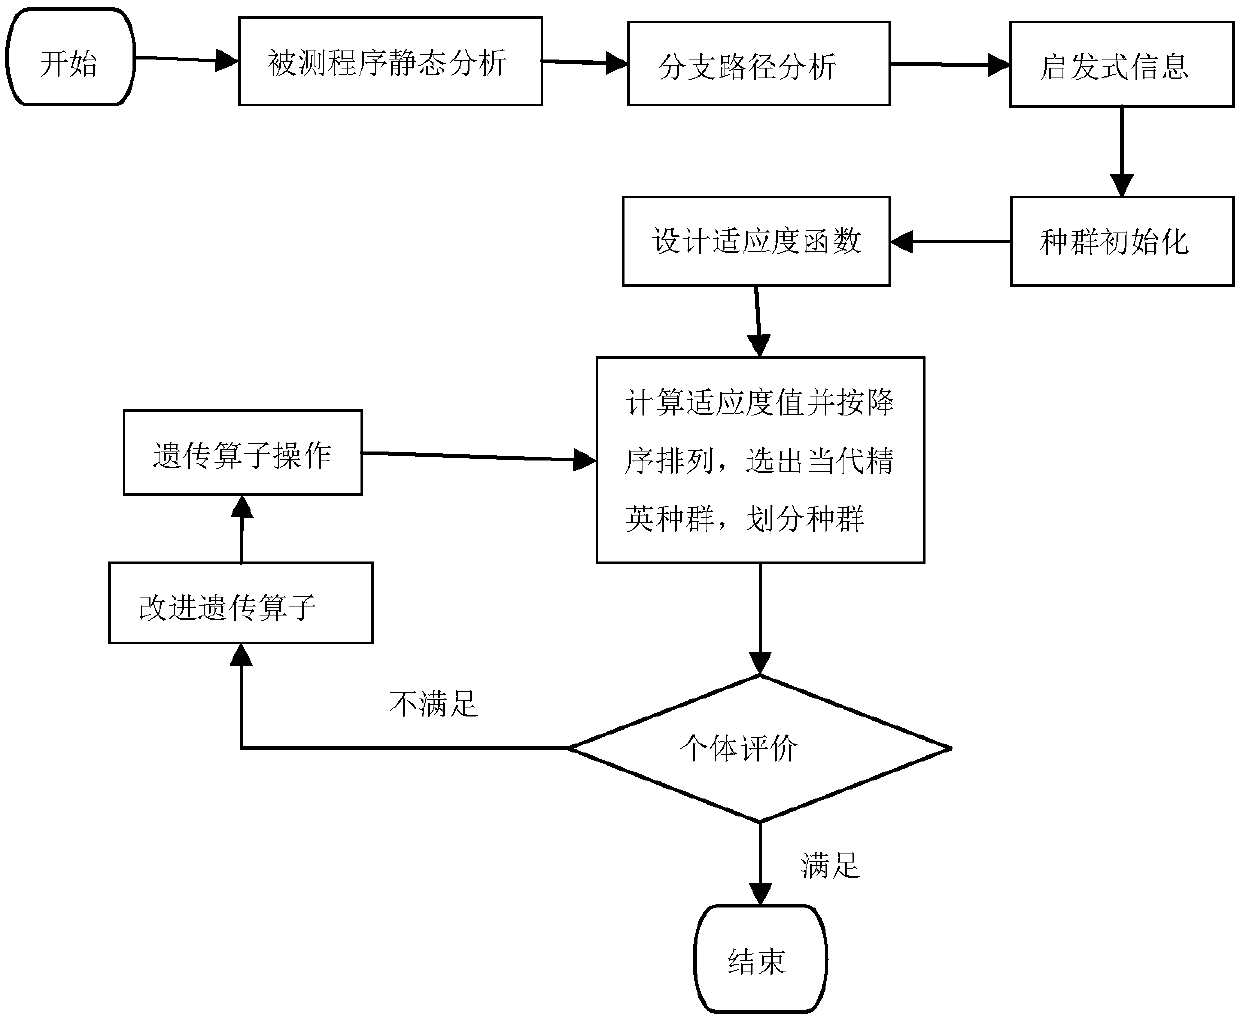
The invention discloses a genetic algorithm optimization-based software test data generation method, and belongs to the field of software testing. The method comprises the steps of performing static analysis on a current tested program to obtain a branch path coverage matrix; by considering the influence of layer proximity, branch distances and branch weights, designing a proper fitness function;in combination with an elite thought, improving a direction and a probability in a genetic operator of a genetic algorithm; selecting an initial population; replacing part of the initial population with a population comprising heuristic information and obtained by the coverage matrix; equally dividing the population; performing parallel genetic algorithm operation by using the improved fitness function and genetic operator; and selecting out optimal software test data meeting the conditions. The convergence speed of the genetic algorithm is increased while the algorithm is prevented from falling into local optimum, and the time cost of software test data generation is reduced.
Owner:HANGZHOU HUICUI INTELLIGENT TECH CO LTD
Method for allocating graticule resource based on paralleling genetic algorithm
InactiveCN101324854AQuality improvementHigh speedResource allocationGenetic modelsQuality of serviceAlgorithm
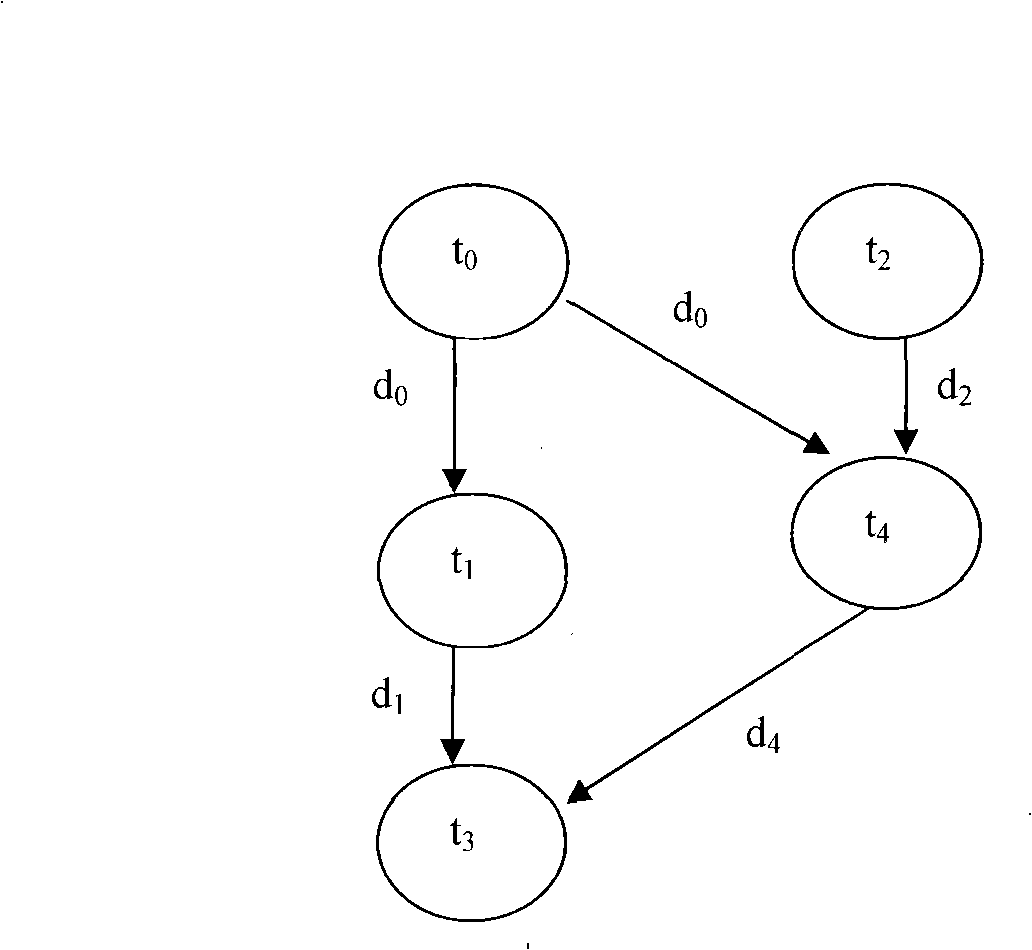
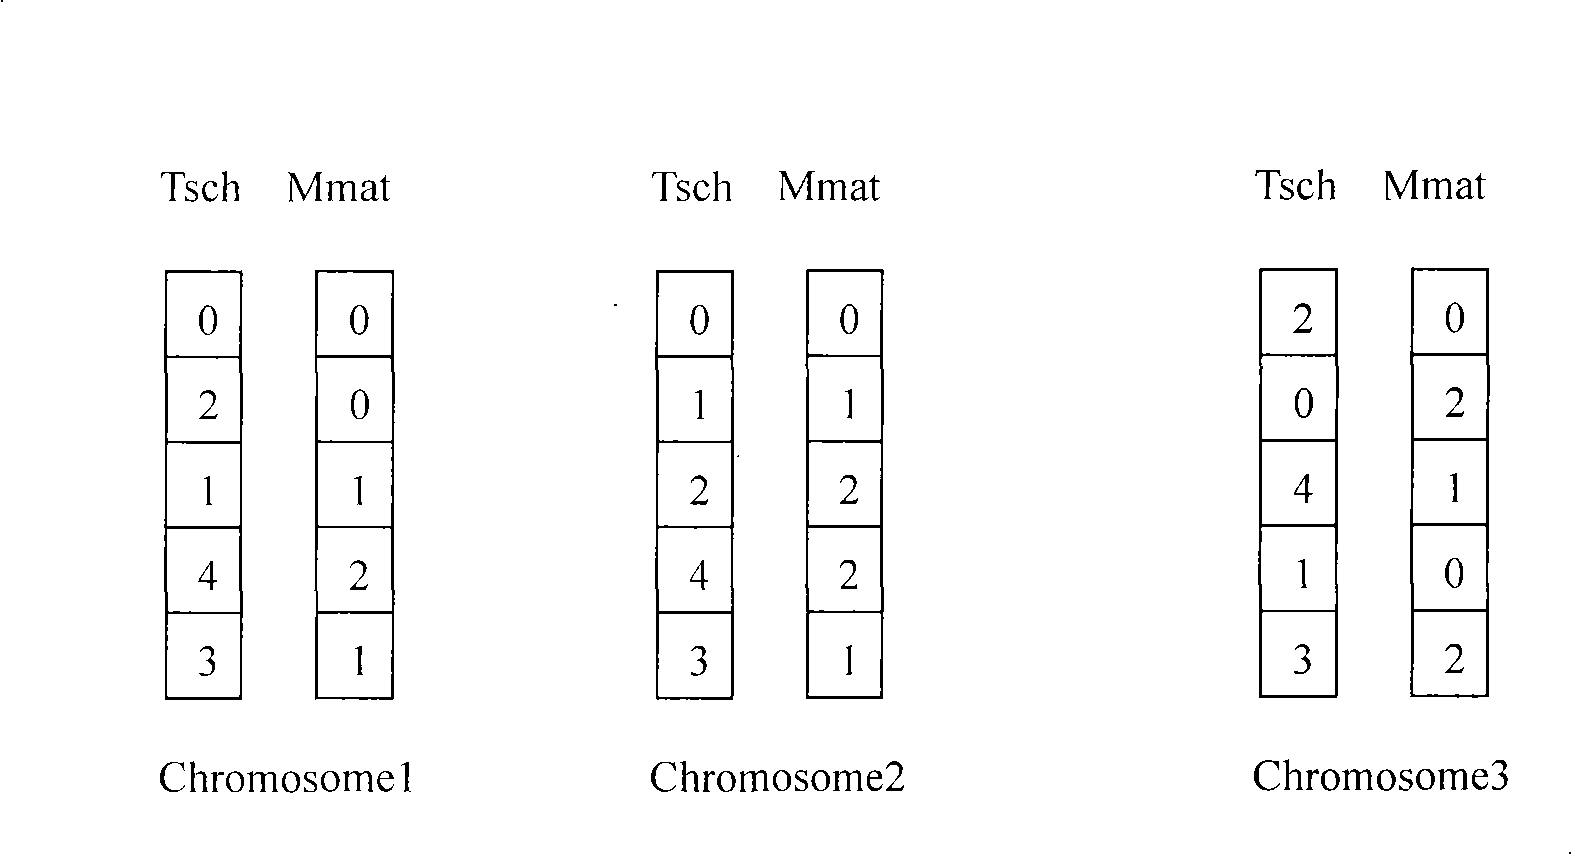
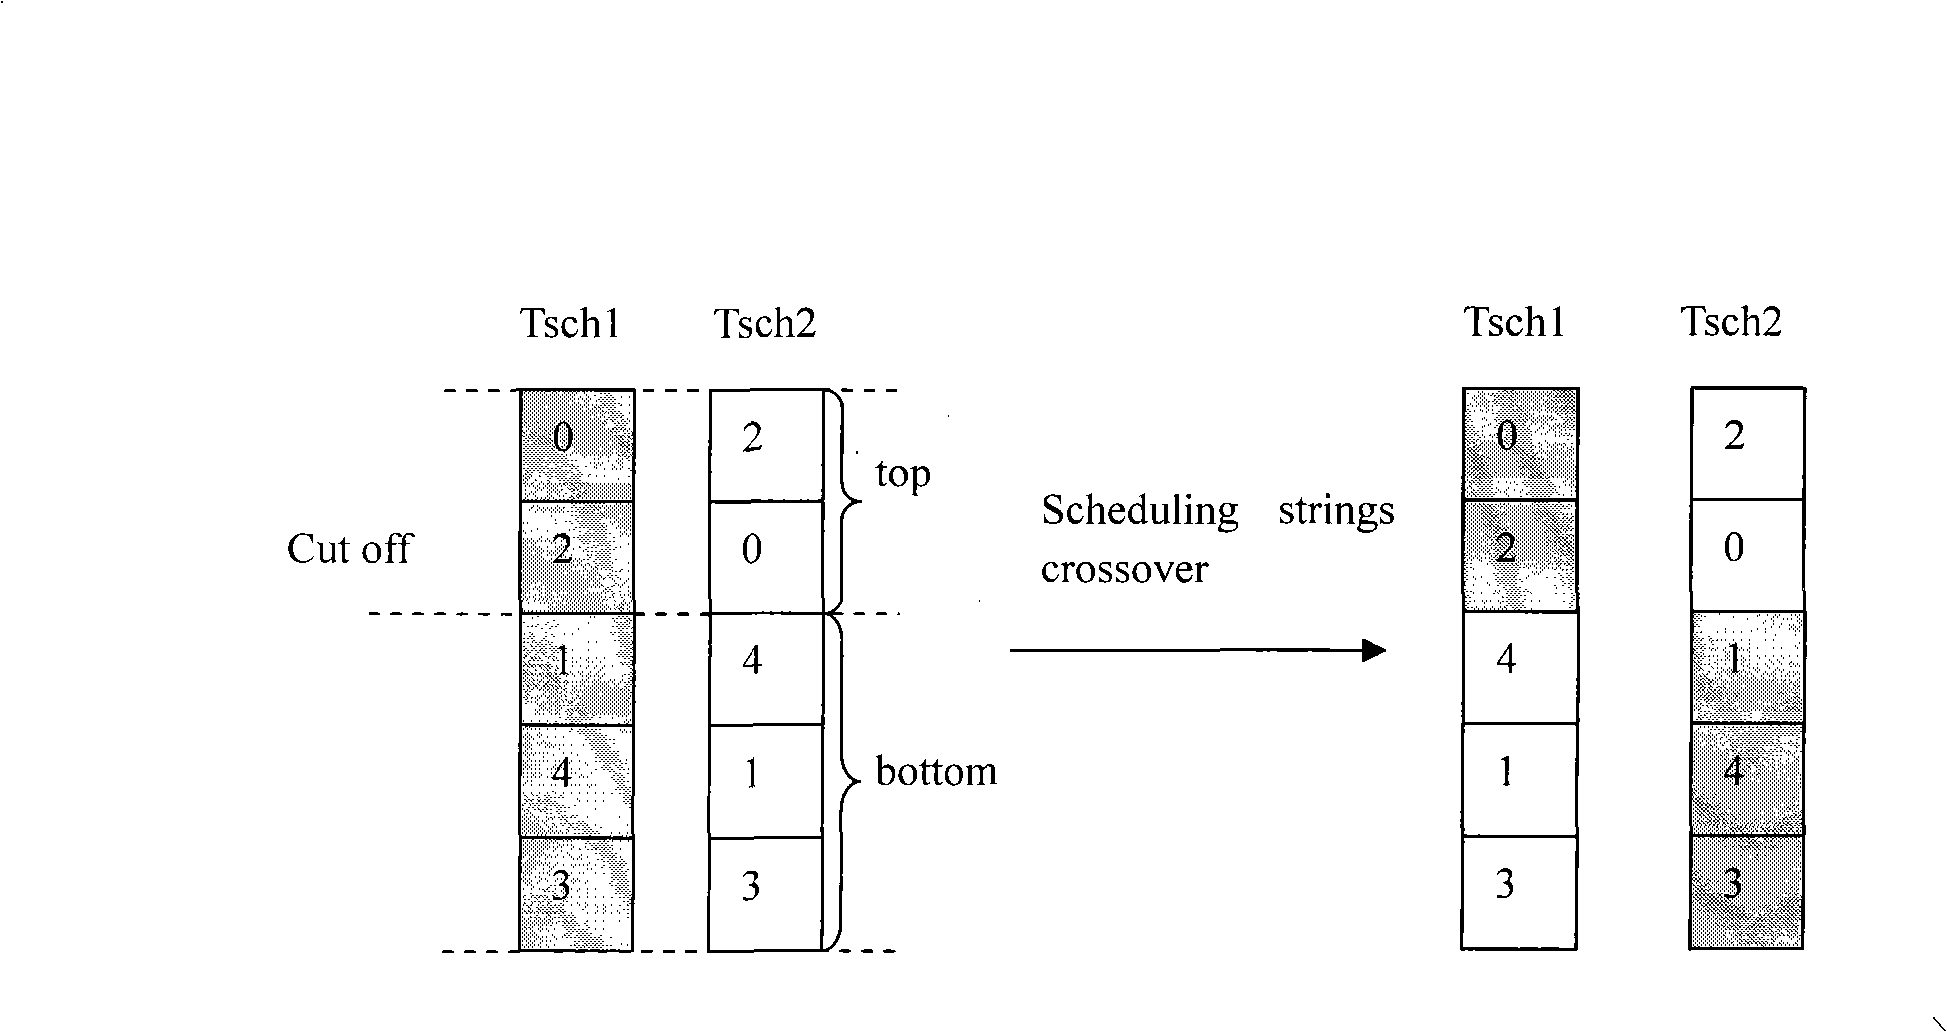
The invention relates to a grid resource allocation method based on a parallel genetic algorithm. The method comprises the following steps: firstly, the information is initialized in a main thread, such as task collection, machine collection, an execution time matrix E of the task, and mapping of a sub-task to the machine, etc.; then a plurality of sub threads are generated and mapped to different processors, an initializing sub-population is independently generated by each sub thread, evolutionary computation is performed in parallel, the optimum individual of each generation is transferred to the main thread, the main thread performs comparison, and the optimum individual is retained; when the predetermined generation arrives, the transfer operation between the sub-groups is performed; and the operation of the main thread and all the sub-groups cannot be finished until the termination conditions are met. The genetic algorithm is taken as the most effective heuristic global stochastic searching method, and the solution of the NP problem can be performed. The quality and the speed for the algorithm for solving are improved by the parallel genetic algorithm proposed according to the natural parallelism of the genetic algorithm, and the method is an effective grid energy resource optimization method and favorable for improving the service quality of the grid.
Owner:WUHAN UNIV OF TECH
Optimization design method of low-noise amplifier based on genetic algorithm
ActiveCN103150459ASave time and costSolve the problem of large amount of calculation and time-consumingSpecial data processing applicationsAviationImpedance matching
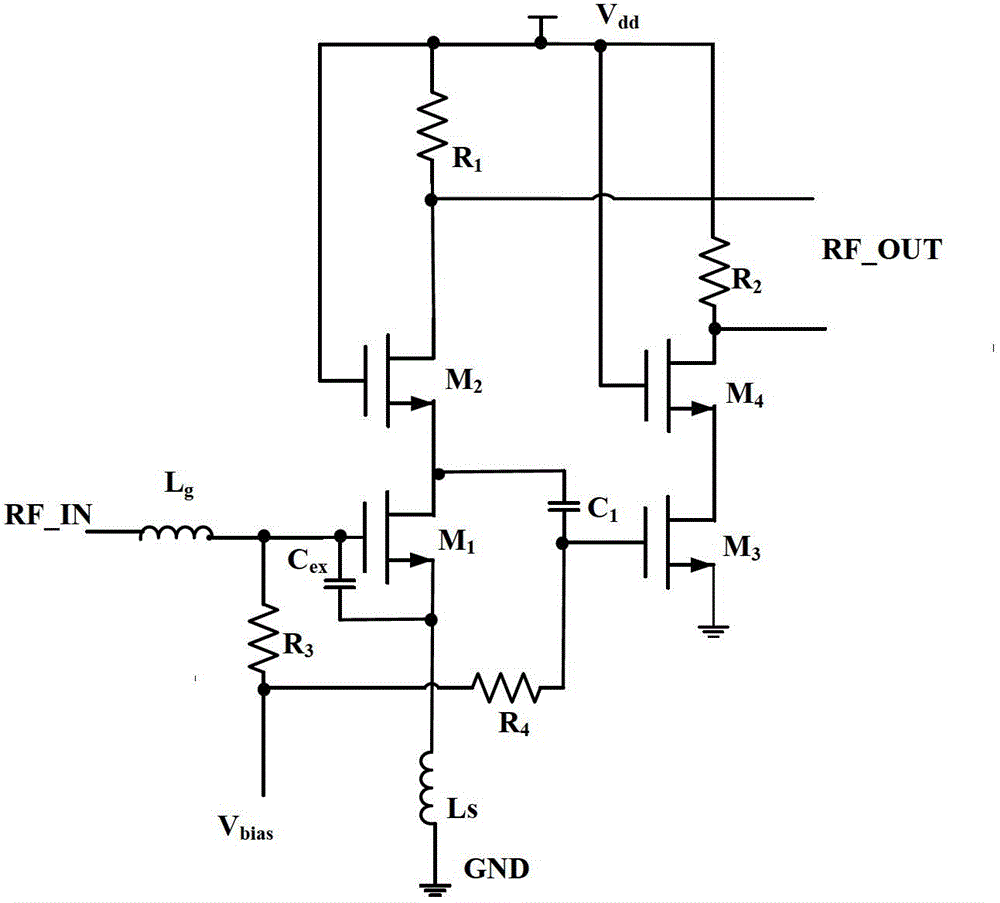
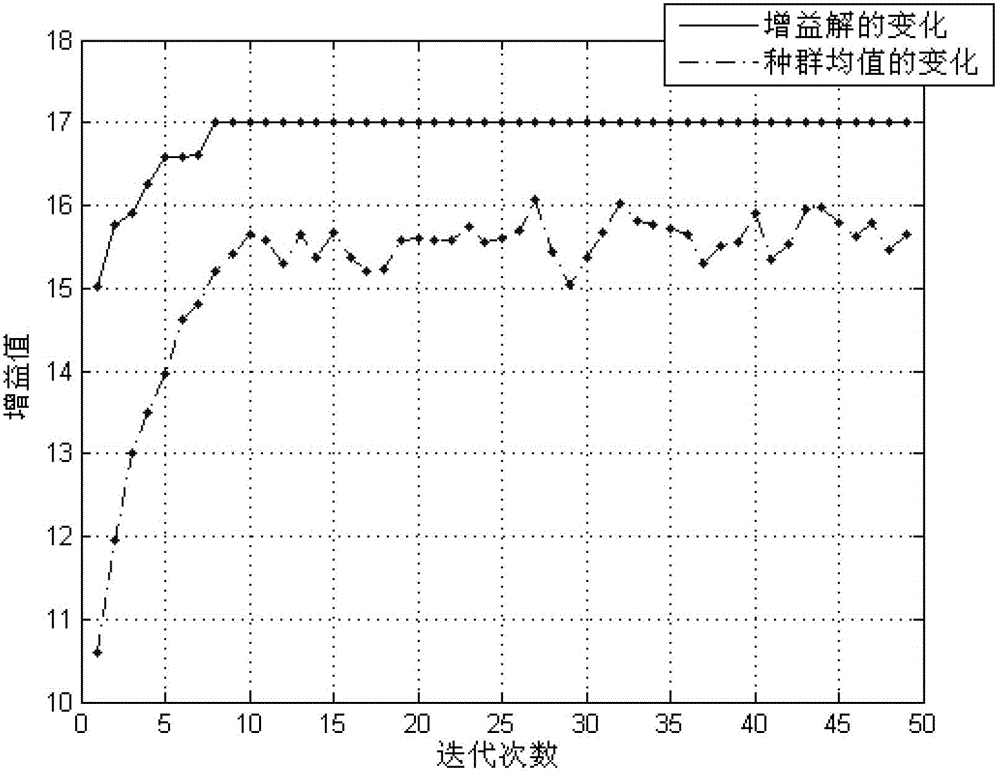
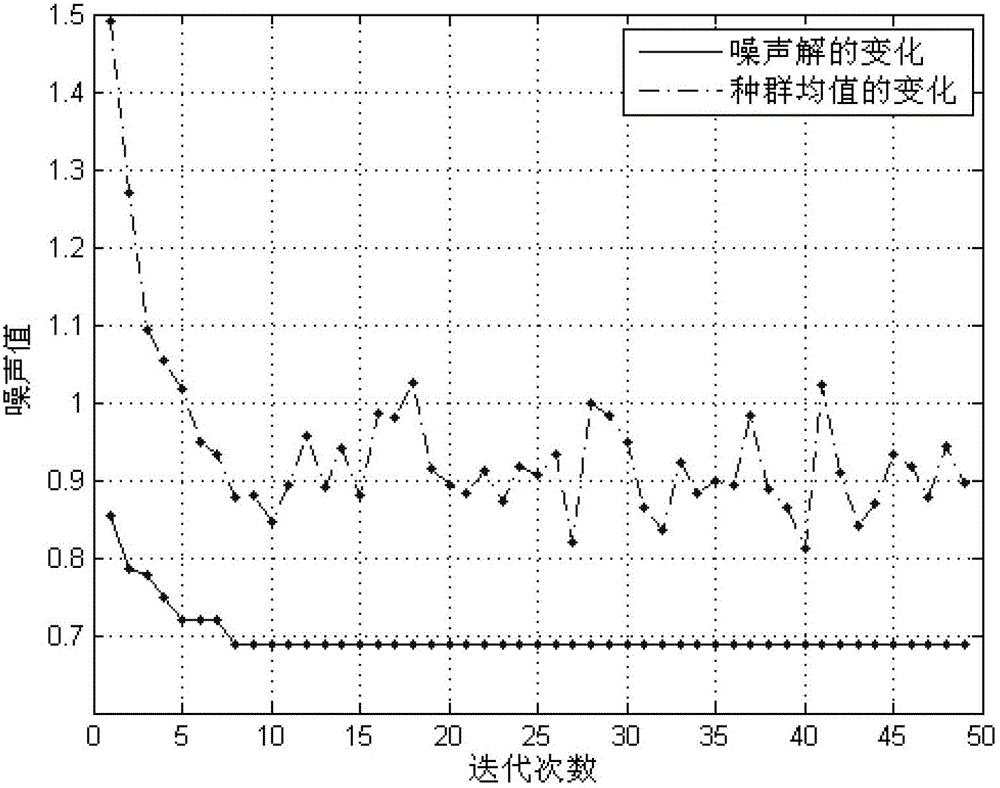
The invention discloses an optimization design method of a low-noise amplifier (LNA) based on a genetic algorithm, and solves the problem of multi-objective optimization in LNA design. Circuit parameters in the LNA such as transistor sizes and passive device values are used as variable quantities, impedance matching of the LNA and a current equation of transistors are used as constraint conditions, a circuit performance evaluation technology based on the equation is used as a circuit performance evaluation method, a parallel genetic algorithm with elitist strategy is used as a global search algorithm, and the gain, noise coefficient and power consumption of the LNA are optimized simultaneously. Through the optimization method, the optimization result of the circuit can be quickly obtained, and the method is extremely suitable for circuit design with particular restriction, performance and function. The method can be used for deep sub-micron radio frequency CMOS (Complementary Metal Oxide Semiconductor) integrated circuit, and is widely applied to electronic systems in the aviation and aerospace fields.
Owner:BEIHANG UNIV
Copper flash smelting operation parameter optimization method
The invention provides a method for optimizing operation parameters in the flash smelting of copper. The invention is aimed at the optimization of the stability in comprehensive operation condition in flash smelting, sets up a mechanism model and an intelligent optimizing model based on a fuzzy C mean clustering chaos pseudo parallel genetic algorithm, and carries out coordinated outputting for the optimized result of the two models by way of intelligent integration. The method can get the optimal operation parameters in the flash smelting of copper, that is, the optimal charge of hot blast and oxygen in a reaction tower of a flash smelting furnace.
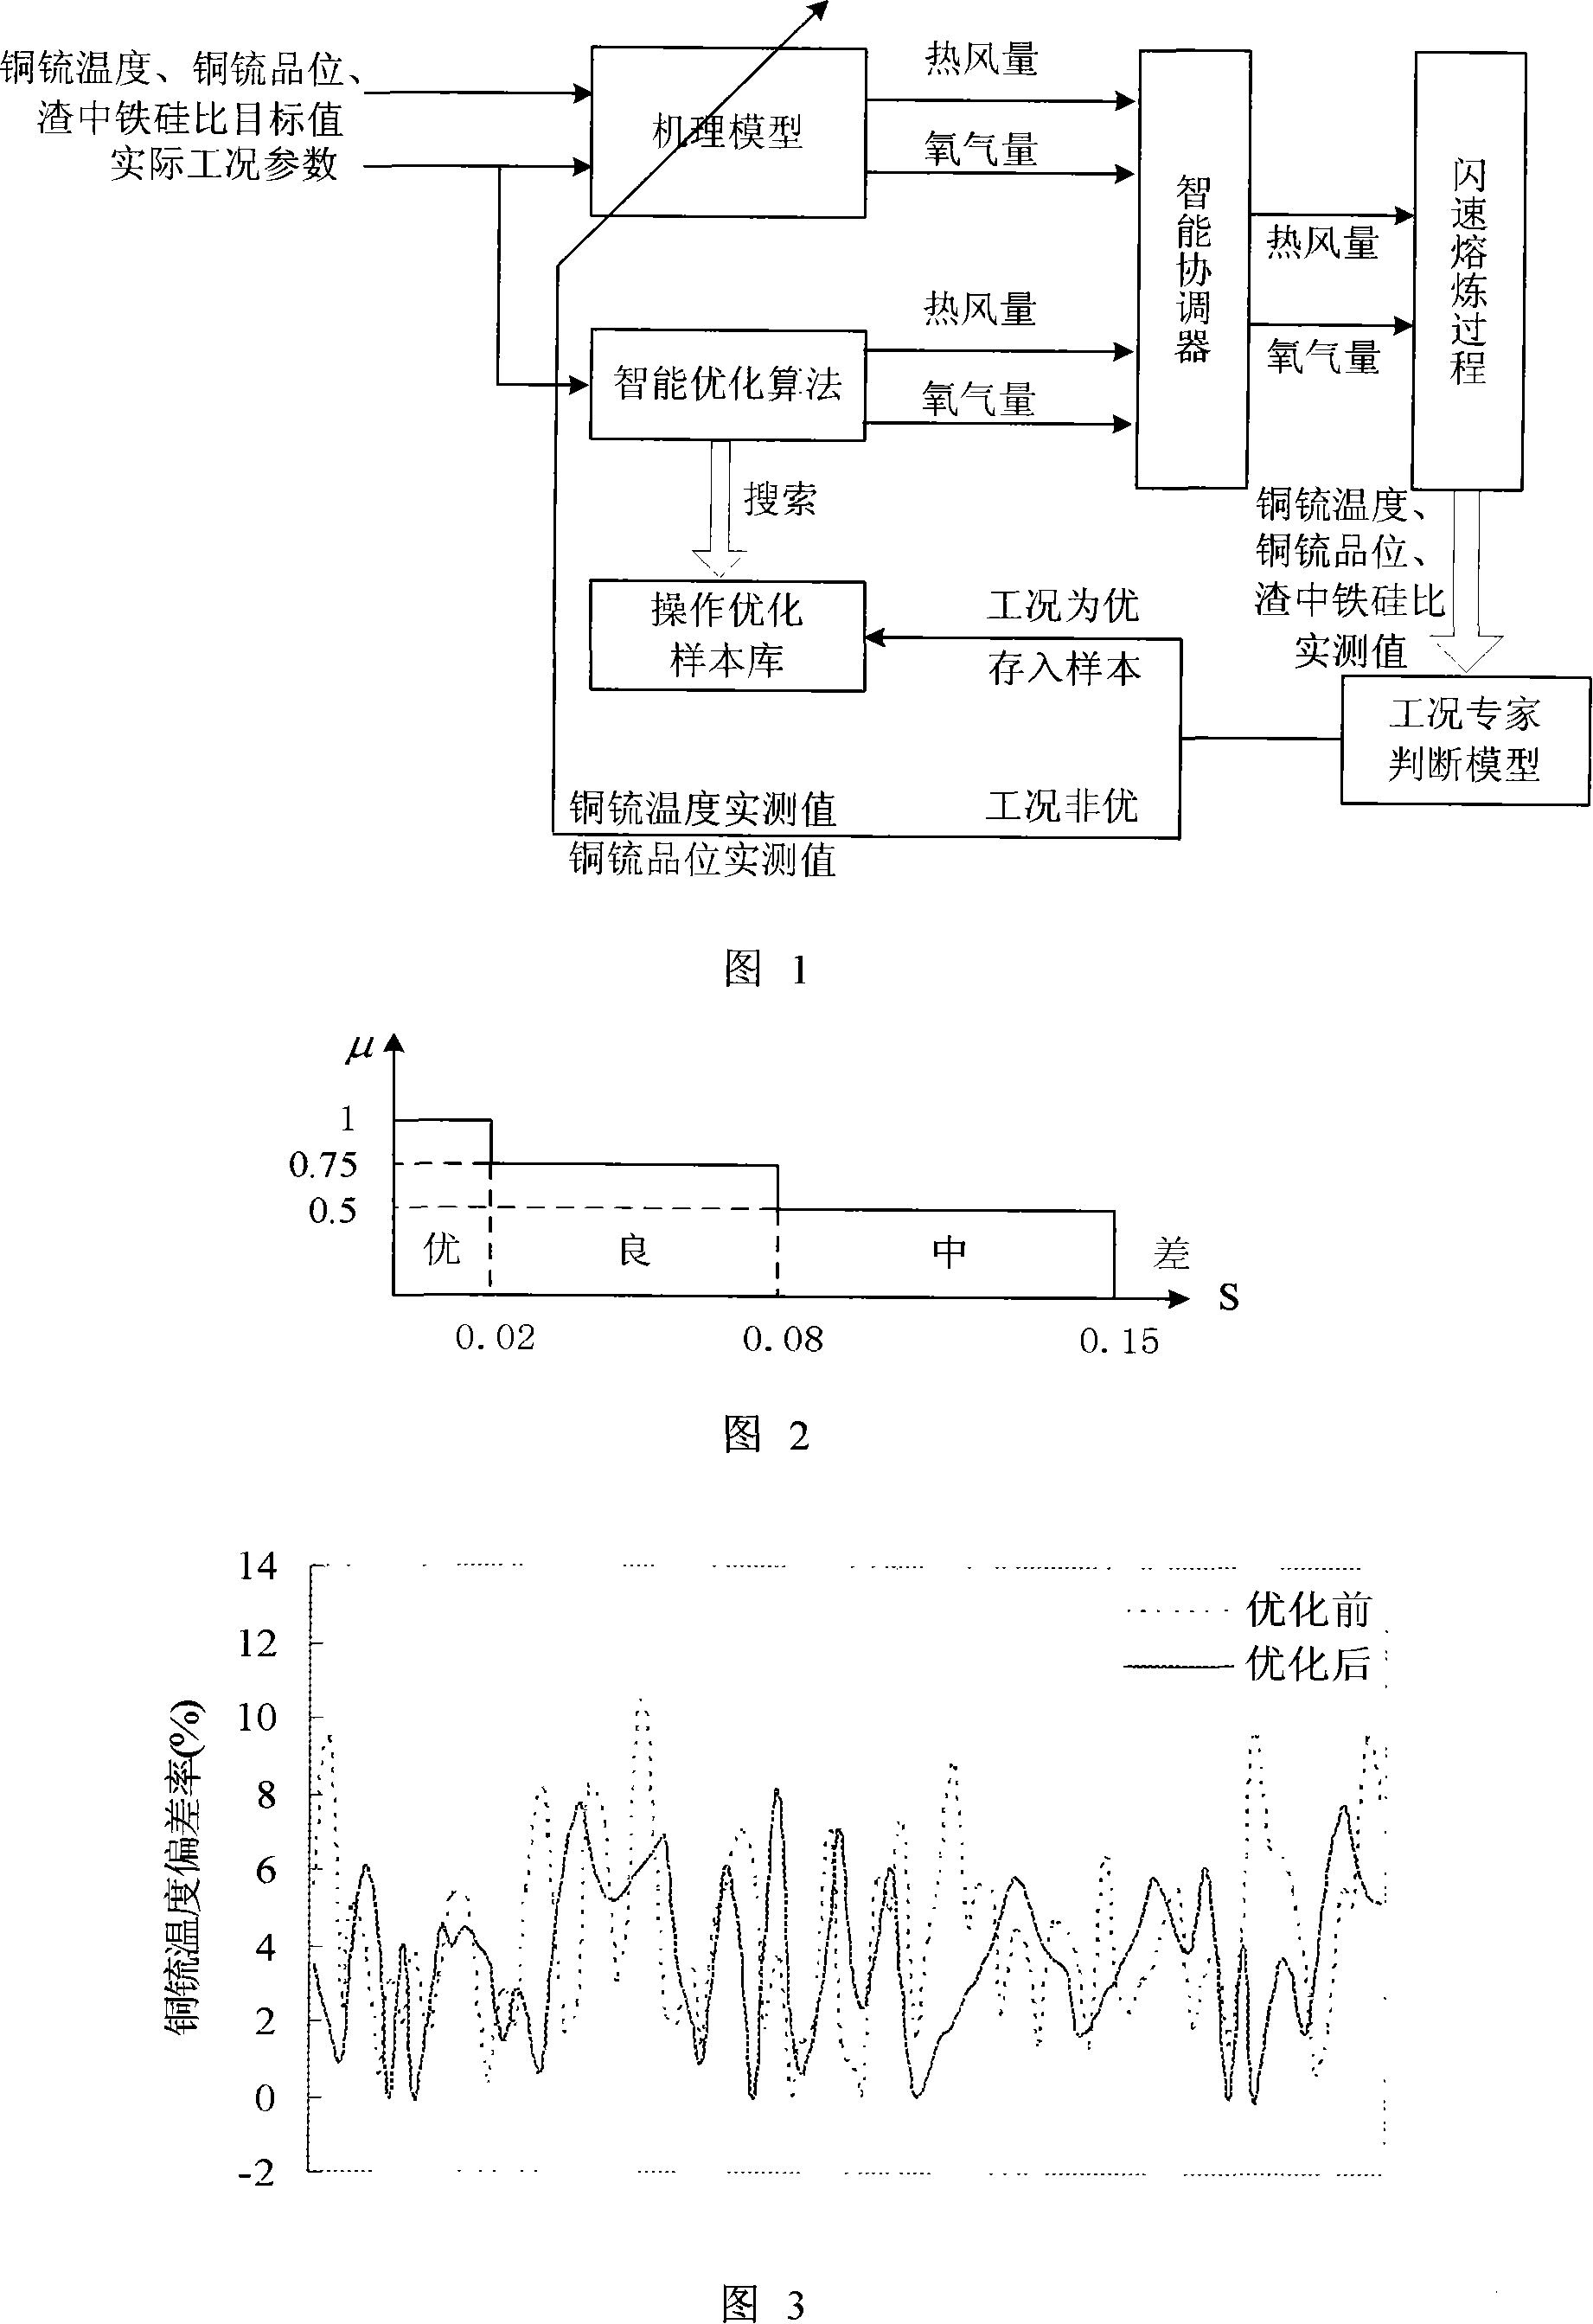
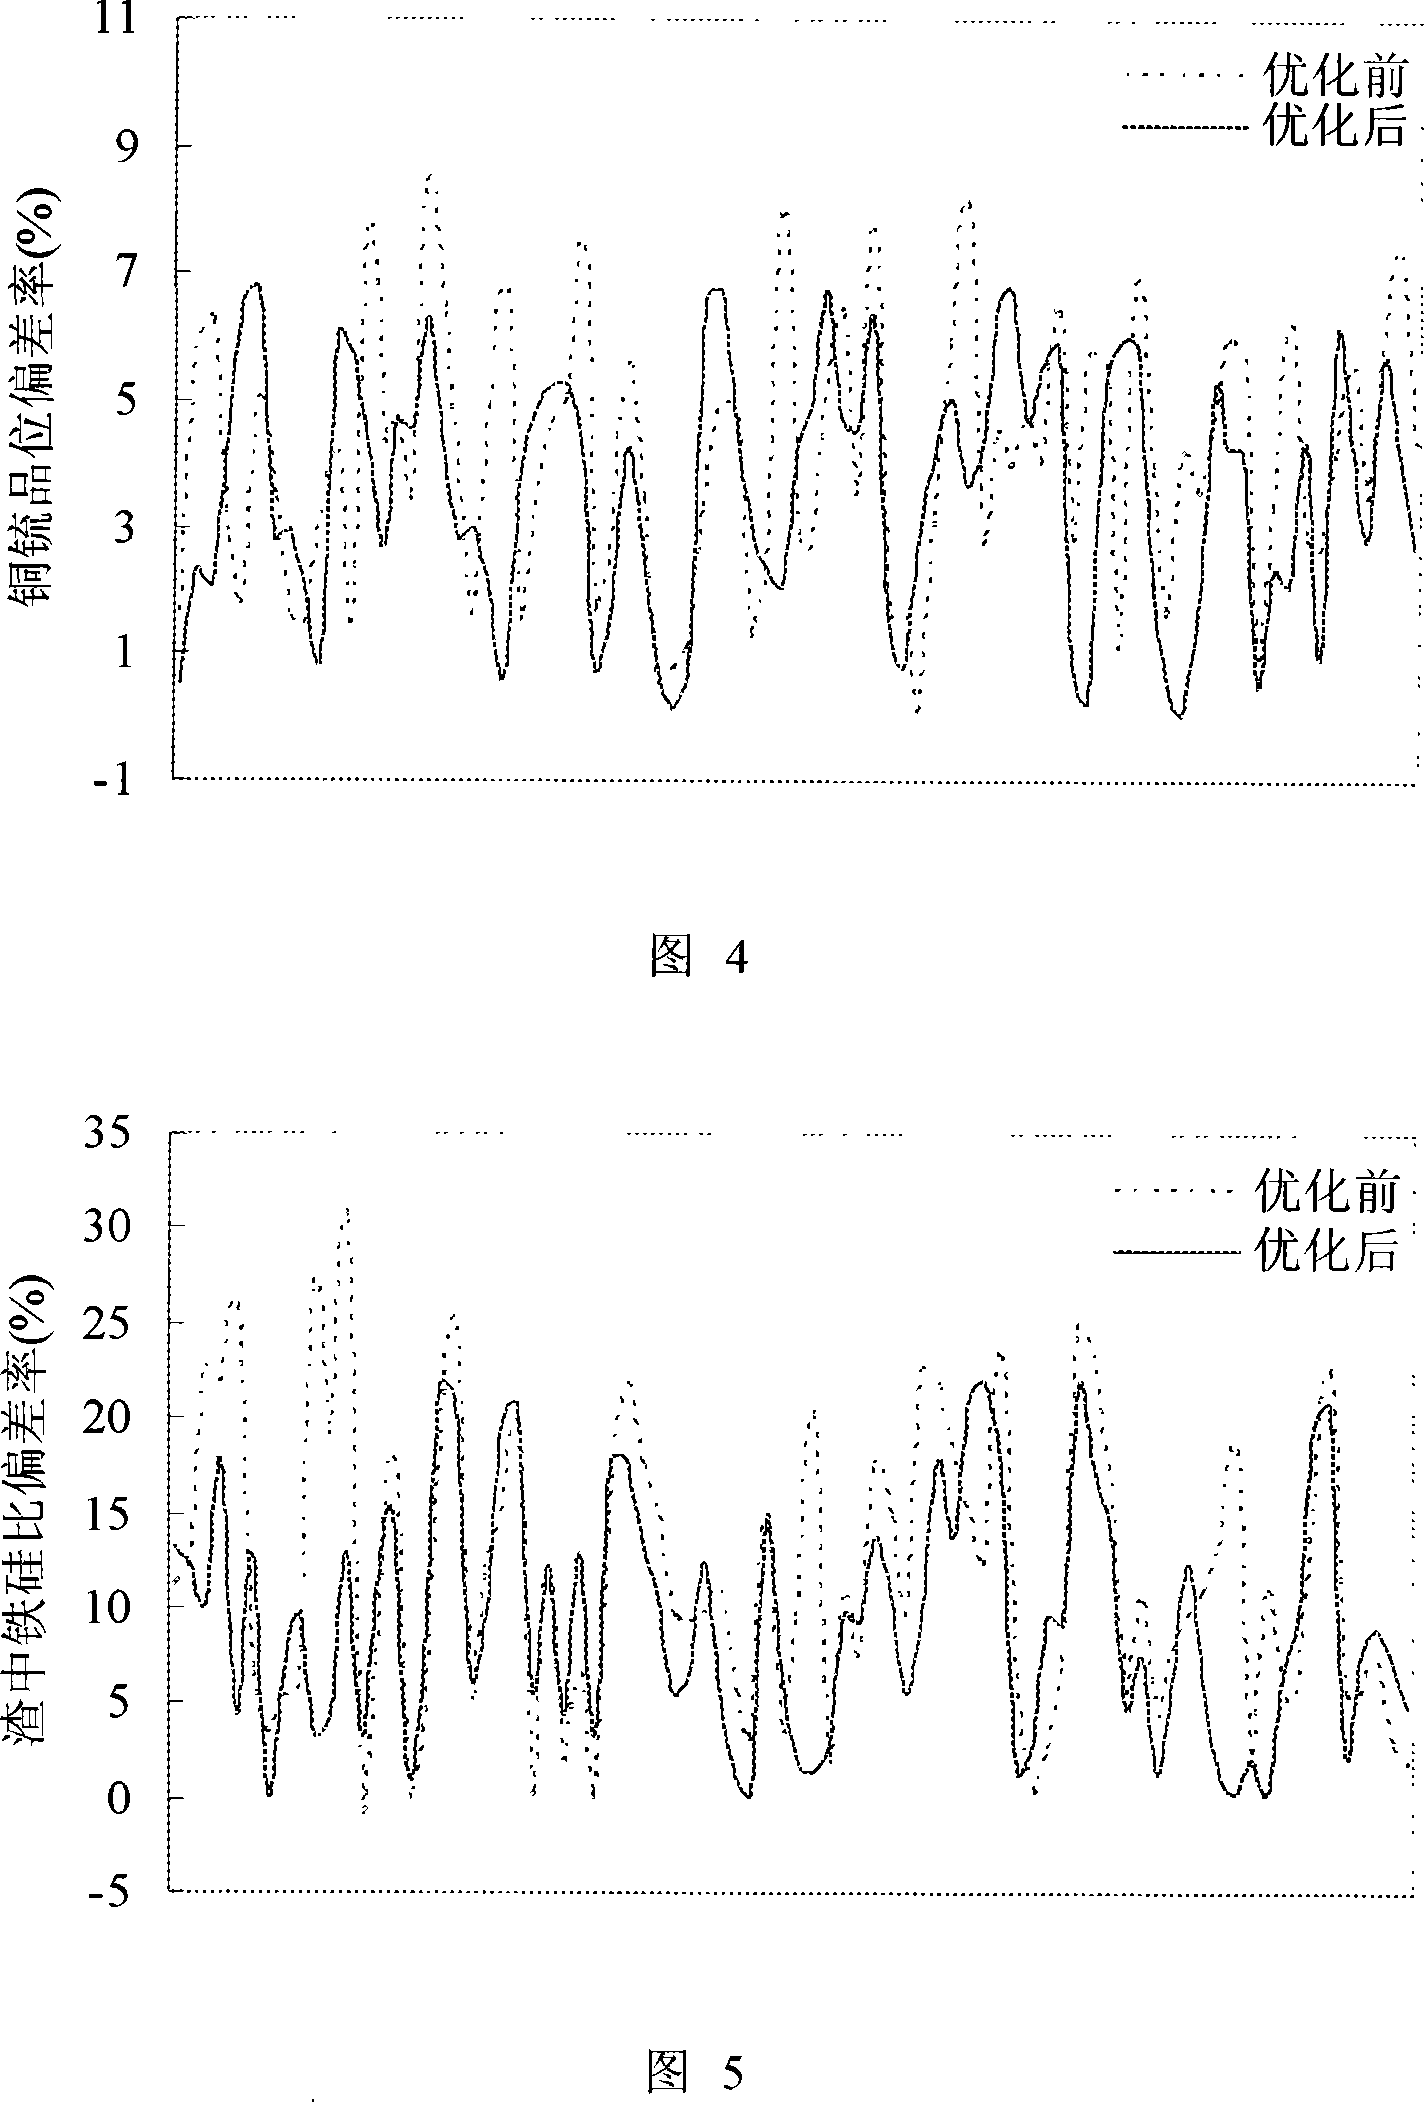
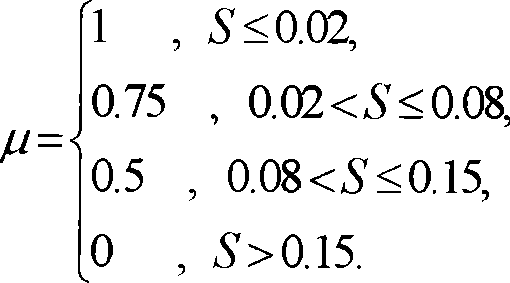
Owner:CENT SOUTH UNIV
Distribution network reconstruction method employing parallel genetic algorithm based on undirected spanning tree
InactiveCN106340873ATroubleshoot refactoring issuesReduce lossGeometric CADSingle network parallel feeding arrangementsSub populationsReconstruction method
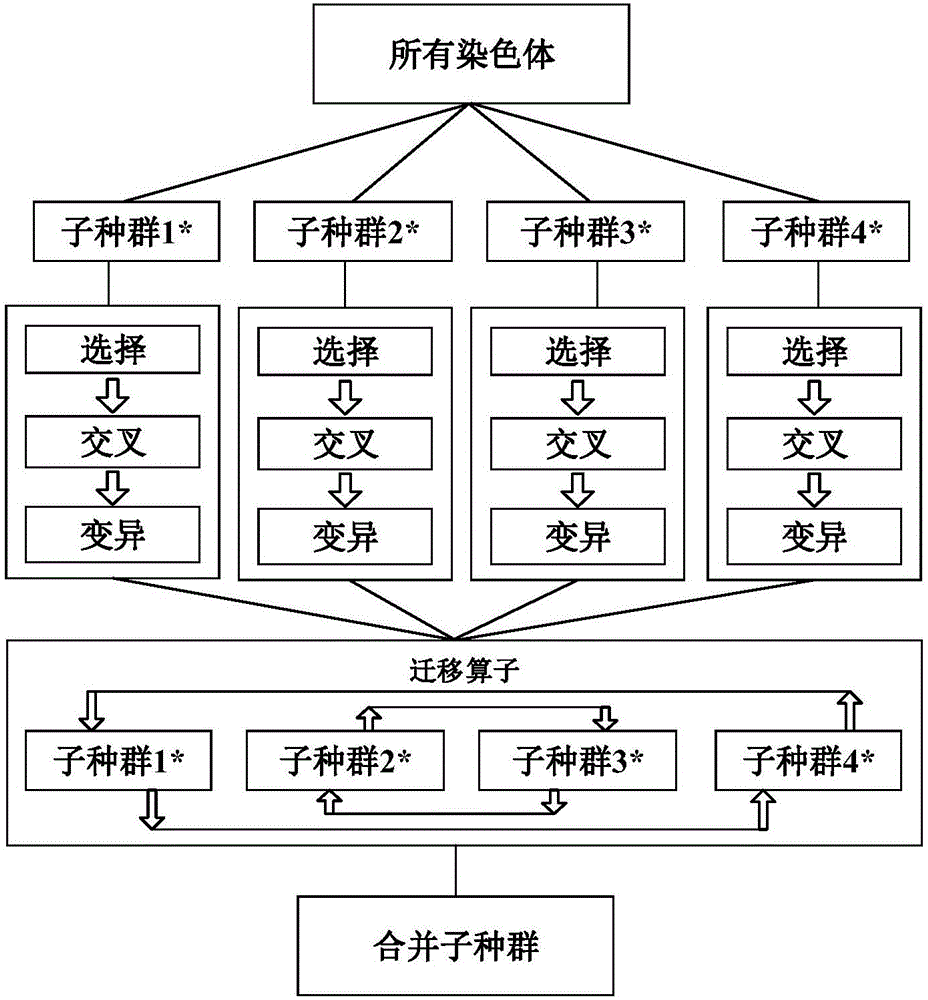
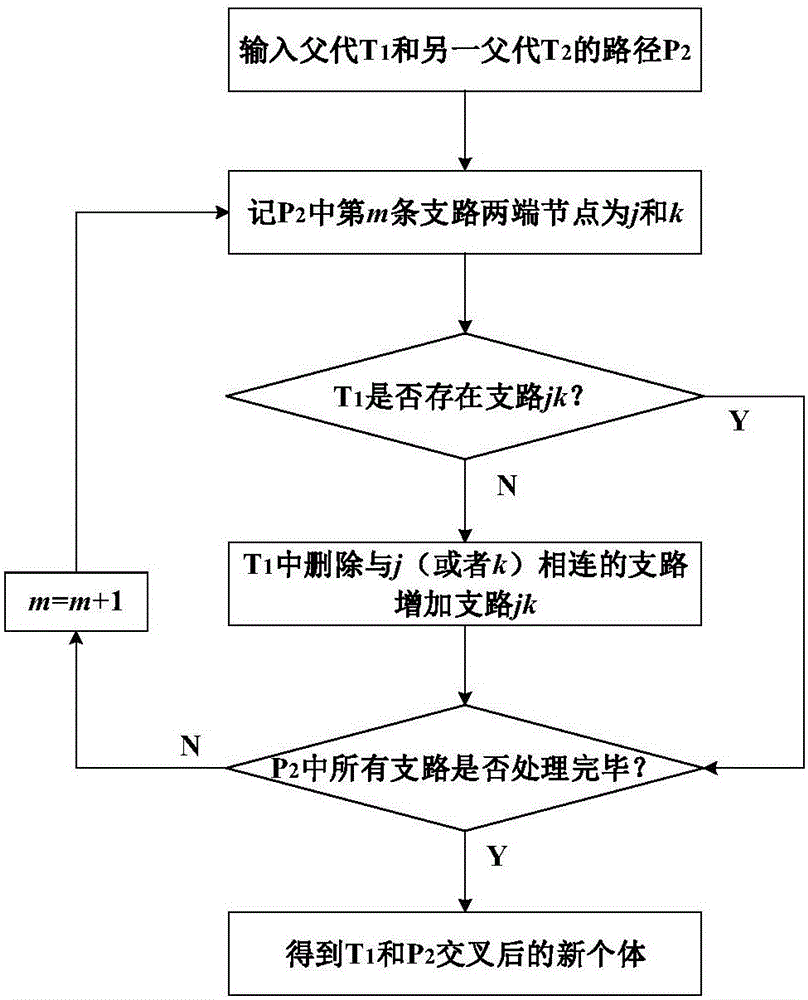
The invention relates to a distribution network reconstruction method employing a parallel genetic algorithm based on an undirected spanning tree. The method comprises the following steps: obtaining parameters; performing Monte Carlo simulation sampling; randomly generating an initial population with feasible topology, and setting an initial value of iteration frequency n as 1; performing load flow calculation; calculating a target function value, determining whether constraint conditions are satisfied, if not, returning to the step for re-generating the initial population, and if yes, dividing an existing population into multiple sub populations for performing parallel genetic operation; generating one random permutation P from 1 to Nsub, and establishing a mapping relation between a target sub population i and a source sub population pi, wherein P=[p1, p2,..., pNsub]; replacing the worst individual of each target sub population with an optimal individual of one corresponding source sub population; and determining whether the iteration frequency n reaches requirements, if not, adding one to the iteration frequency and returning to the step of load flow calculation, and if yes, outputting a distribution network reconstruction scheme. Compared to the prior art, the method has the advantages of high calculation efficiency, high integration, close connection with reality and the like.
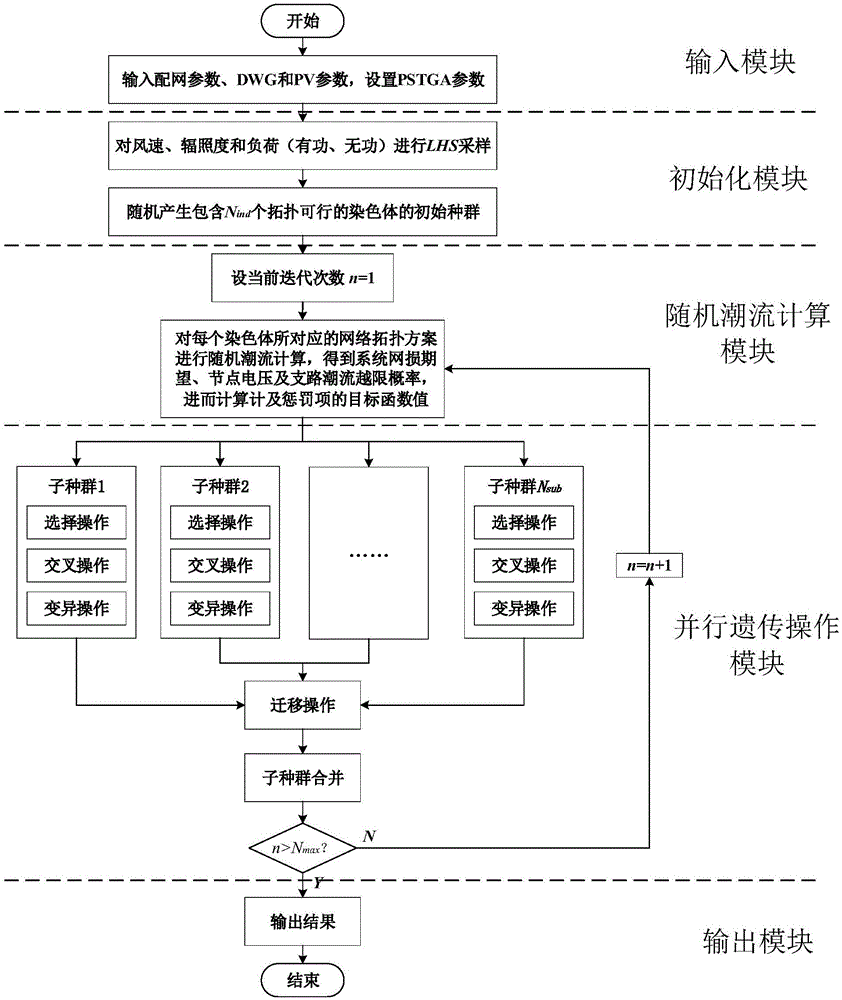
Owner:SHANGHAI JIAO TONG UNIV +1
AGV scheduling optimization method based on two-stage multi-population parallel genetic algorithm
InactiveCN107274124AFast convergenceAvoid entering convergence prematurelyLogisticsResearch ObjectMinimum time
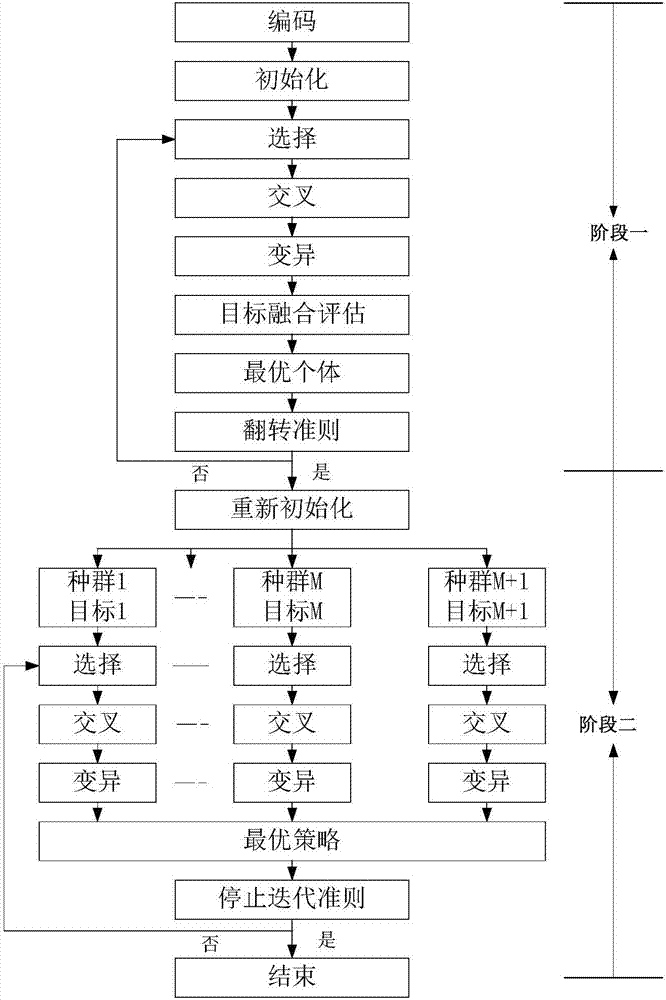
An AGV scheduling optimization model is built with goods cabinets, sorting tables and AGVs as scheduling research objects and minimum time for AGVs to complete a specified task as an optimization objective. The AGV scheduling optimization model is solved using a two-stage multi-population parallel genetic algorithm and a simulated annealing algorithm, and the algorithms are solved by means of parallel computation to get an optimal scheduling scheme of AGVs for a specified task. Populations can be prevented from converging too early. The computational efficiency is improved. The algorithms can deal with a large-scale scheduling optimization problem.
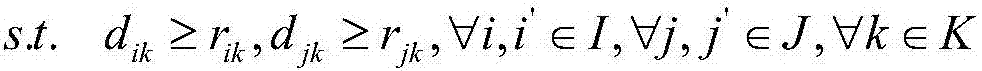
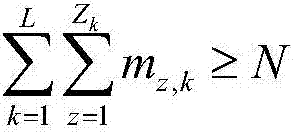
Owner:QUANZHOU INST OF EQUIP MFG
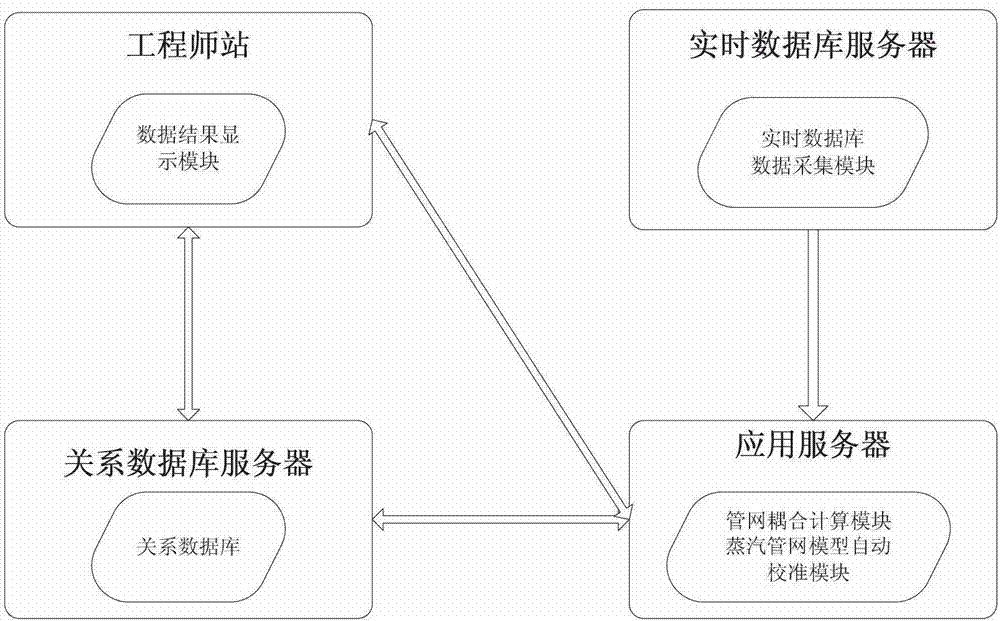
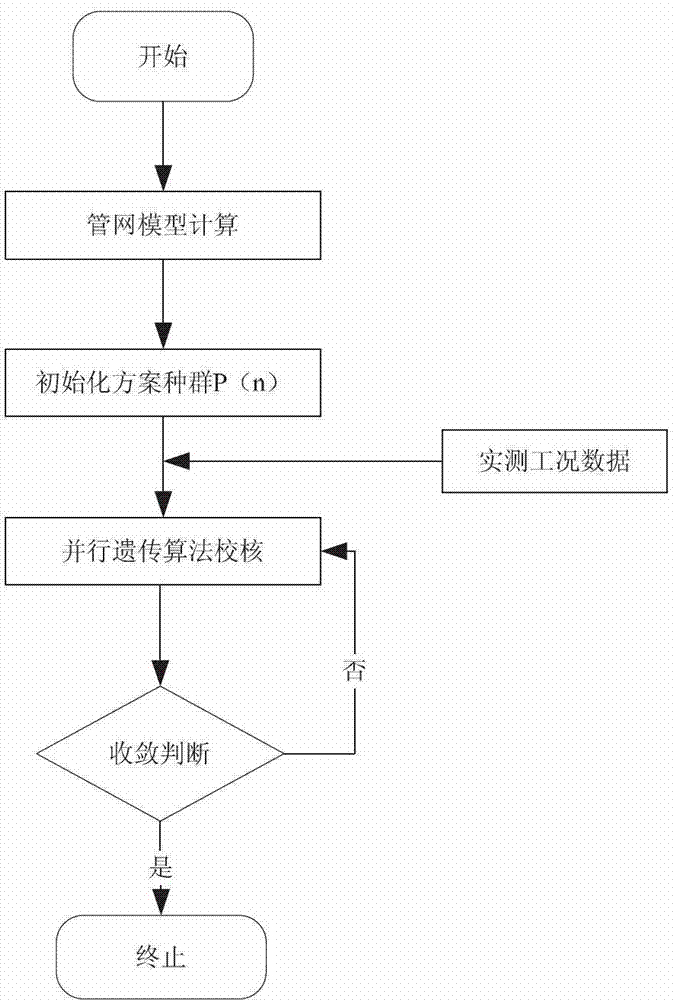
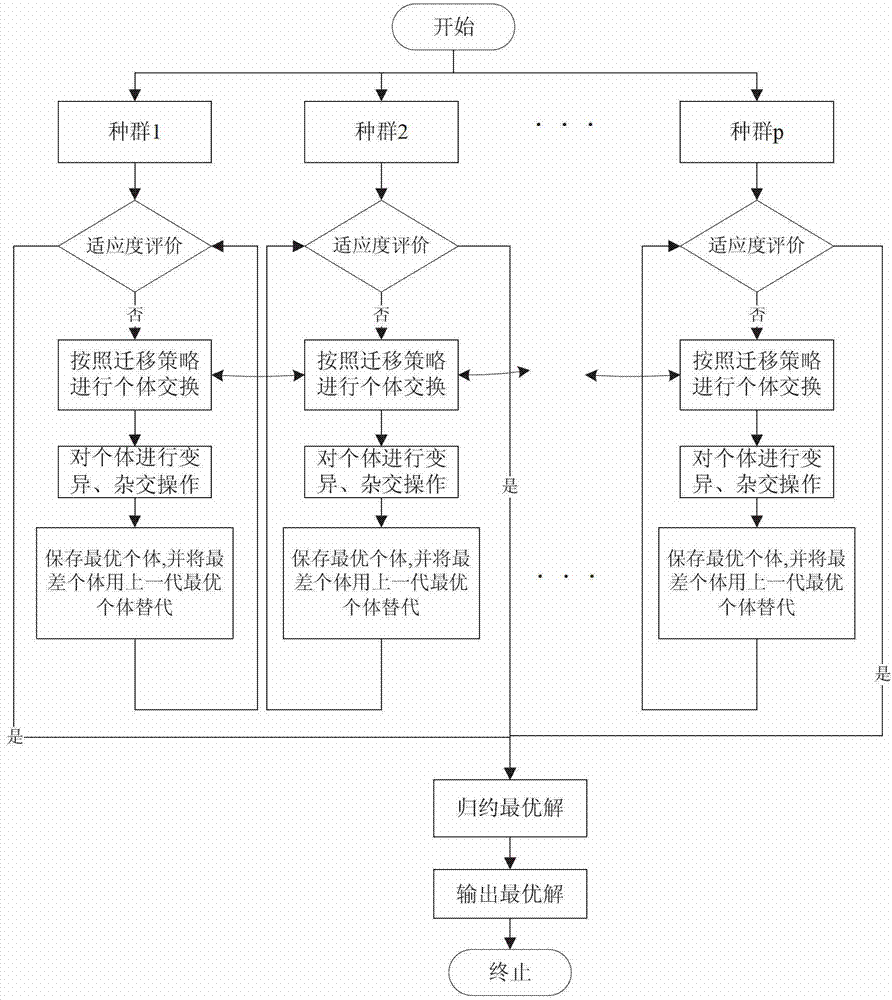
Parallel genetic algorithm steam pipe system model auto-calibration system based on TBB (threading building block)
InactiveCN102867090ASpeed up searchIncrease mutation rateGenetic modelsSpecial data processing applicationsRelational databaseData acquisition
The invention discloses a parallel genetic algorithm steam pipe system model auto-calibration system based on a TBB (threading building block) and belongs to the field of steam pipe system model calibration and calculation. A hardware system comprises a relational database server, a real-time database server, an application server and an engineer station, wherein the relational database server is connected with the engineer station and the application server; and the application server is also connected with the real-time database server and the engineer station, so that data exchange among the application server, the real-time database server and the engineer station is kept. An application module comprises a relational database, a data acquisition module, a data result display module, a hydraulic thermal coupling calculation module and a pipe system model auto-calibration module. The parallel genetic algorithm steam pipe system model auto-calibration system has the advantage that quick and accurate steam pipe system model calculation is realized. Therefore, pipe system model calculation is more accurate, and analysis and maintenance on a pipe system are more facilitated.
Owner:AUTOMATION RES & DESIGN INST OF METALLURGICAL IND +1
Large-scale symbol regression method and system based on adaptive parallel genetic algorithm
ActiveCN110135584AImprove search capabilitiesImprove local search capabilitiesGenetic algorithmsGenetic programming algorithmProcess module
The invention discloses a large-scale symbol regression method and system based on an adaptive parallel genetic algorithm, and the system comprises a main process module which is used for initializingand calling a CPU thread module and realizing a synchronization barrier and migration operation; a CPU thread module which is used for executing a genetic programming algorithm, realizing EV updatingand calling the GPU adaptive value evaluation module; and a GPU adaptive value evaluation module which comprises a CPU auxiliary thread, a CUDA library function and a CUDA self-defined function and is used for executing adaptive value evaluation. According to the invention, a self-adaptive multi-population evolution mechanism and a parallel computing system of heterogeneous computing resources are introduced into a genetic programming algorithm; effective construction elements are successfully extracted by applying an adaptive multi-population evolution mechanism, so that the performance of agenetic programming algorithm in a complex problem of the multi-construction elements is improved, and by designing a parallel computing system of heterogeneous computing resources, computing resources of a CPU (Central Processing Unit) and a GPU (Graphics Processing Unit) are fully utilized, and the searching efficiency is remarkably improved.


Owner:SOUTH CHINA UNIV OF TECH
Using global and local catastrophes across sub-populations in parallel evolutionary computing
InactiveUS20130173512A1Digital computer detailsElectric digital data processingSpecific populationCurrent generation
A parallel genetic algorithm computing process tracks forward progress of a first sub-population across generations thereof. The first sub-population is one of a plurality of sub-populations that form a population of candidate solutions to an optimization problem. At a current generation of the first sub-population, it is determined that forward progress of the first sub-population fails a set of one or more forward progress criteria. In response to determining that the forward progress of the first sub-population fails the set of one or more forward progress criteria at the current generation, a local catastrophe is invoked on the current generation of the first sub-population. The first sub-population is re-populated after the local catastrophe is invoked. The first sub-population is re-established after re-populating while constraining migration to the first sub-population.


Owner:IBM CORP
Vehicle omni-directional following method based on UWB and laser radar sensor
ActiveCN111240341AFollow up in real timeImprove mapping accuracyAutonomous decision making processParticular environment based servicesObstacle avoidance algorithmGenetics algorithms
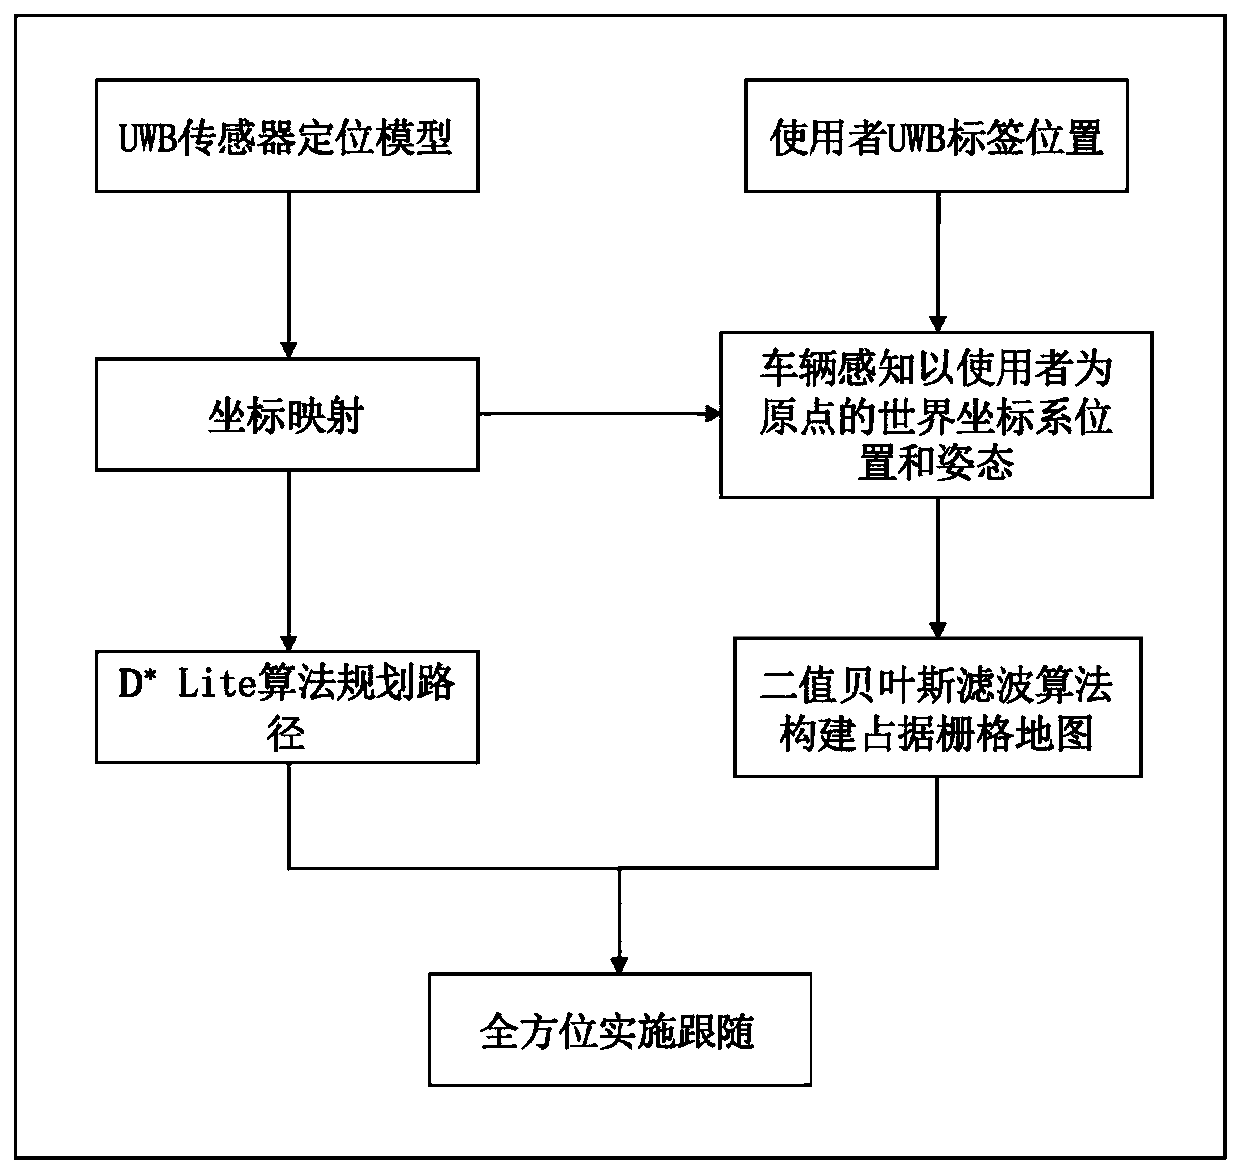
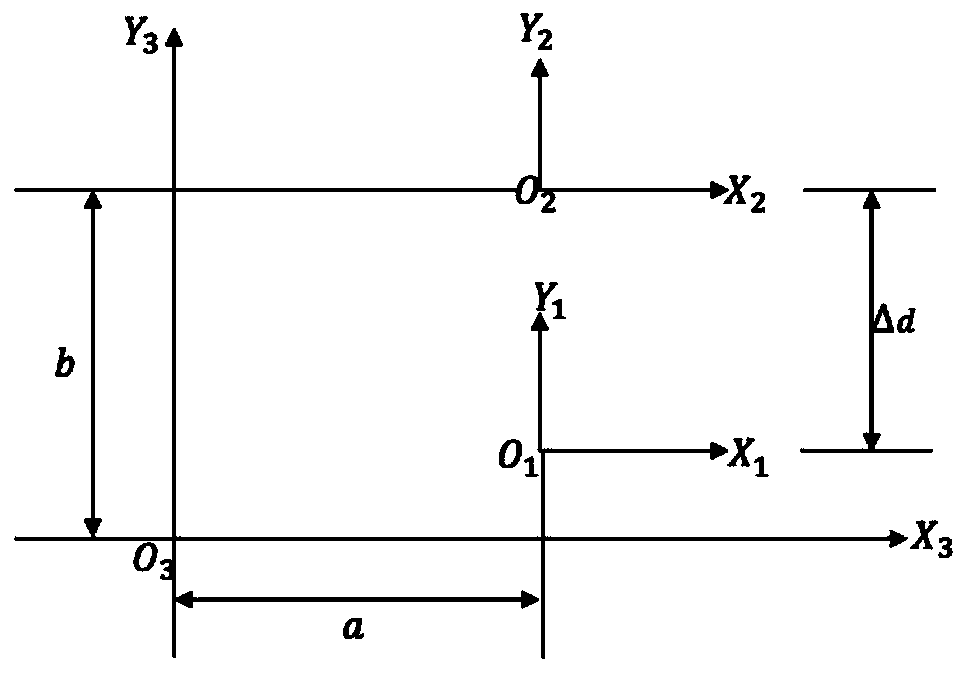
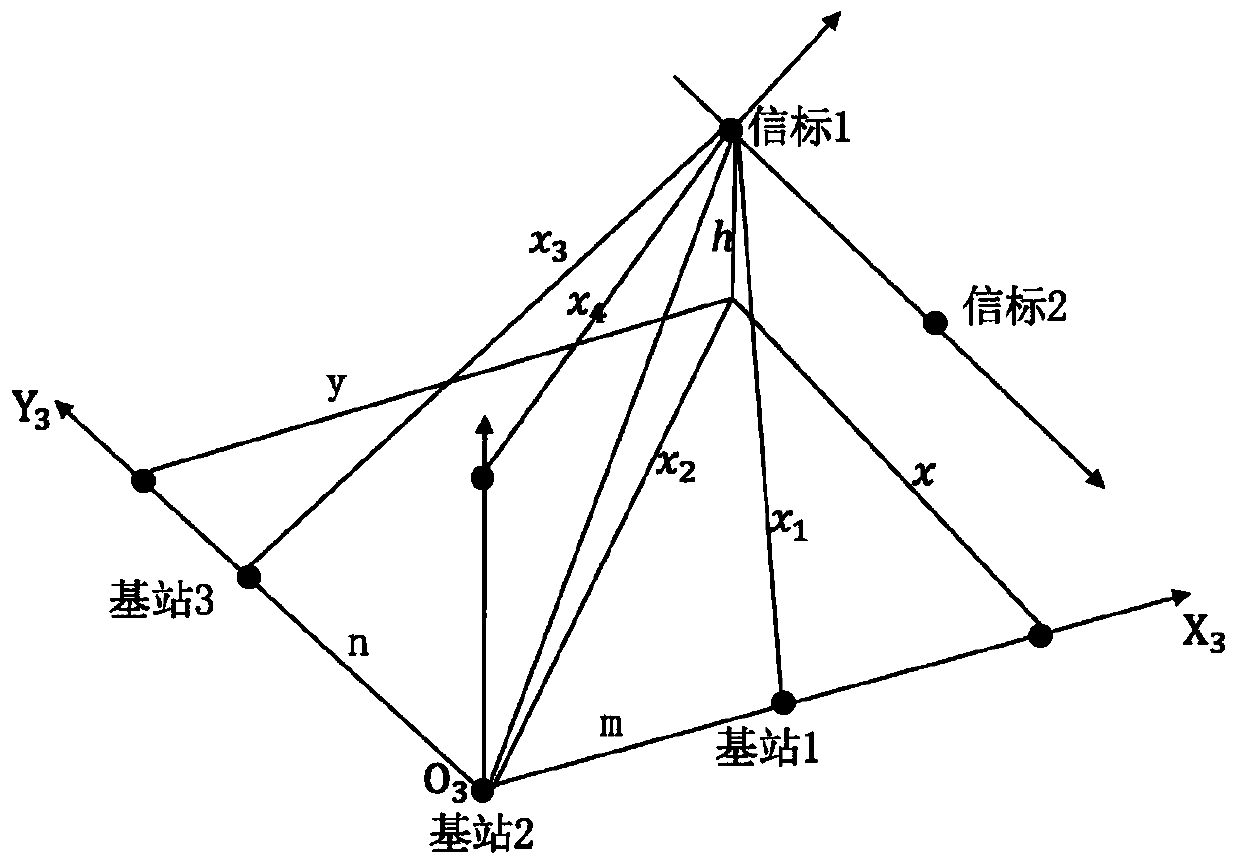
The invention discloses a vehicle omni-directional following method based on UWB and a laser radar sensor. The method comprises the following steps: firstly, establishing a vehicle coordinate system,a laser radar coordinate system and a UWB sensor coordinate system, establishing a world coordinate system, and performing coordinate mapping between the world coordinate system and the vehicle coordinate system; then, enabling the vehicle to sense the position and posture of the vehicle in a world coordinate system with an artificial origin in real time; acquiring obstacle information by using the laser radar sensor, converting coordinates of an obstacle in a laser radar coordinate system into coordinates in the vehicle coordinate system, and constructing an occupied grid map by using a binary Bayesian filtering algorithm; and finally, enabling the vehicle to realize real-time following in any direction based on an occupied grid map and an automatic following and obstacle avoidance algorithm based on a parallel genetic algorithm. The method is simple in algorithm and high in positioning precision, and can realize omnibearing real-time following of the autonomous vehicle around the user.
Owner:NANJING UNIV OF SCI & TECH
Database multi-connection query optimization method based on evolutionary algorithm
InactiveCN107463702ASolve the problem of weak search abilityGood global search abilitySpecial data processing applicationsMerge sortQuery optimization
The invention discloses a database multi-connection query optimization method based on an evolutionary algorithm. According to the method, first, a data preprocessing technology and a bidirectional semi-connection technology are introduced into an SDD-1 algorithm, projection and other unary operation are adopted to simplify data, meanwhile, data of all nodes is ordered by merging, and row data and column data can be reduced at the same time through the bidirectional semi-connection technology; second, all beneficial bidirectional semi-connections are calculated and added into a set BS, a parallel genetic algorithm is adopted to solve a connection query strategy of the SDD-1 algorithm, a group initialization method, a fitness function and a relevant genetic operator suitable for the problem are constructed, and a protocol optimal query path for solving the problem is obtained; and last, the query path is used to initialize a pheromone matrix of an ant colony algorithm, a multi-ant-colony optimization method is utilized to solve an optimal query path again, and the problem that the parallel genetic algorithm has a weak local search ability is solved.


Owner:CAS OF CHENGDU INFORMATION TECH CO LTD
Spark-based parallel genetic algorithm
The invention discloses a Spark-based parallel genetic algorithm, including fitness value calculation parallelization and genetic manipulation parallelization, an RDD of Spark is created from an initial population, the RDD is divided into a plurality of partitions to be distributed to a plurality of nodes of a cluster, each partition corresponds to a sub-population, calculation of a fitness valueis performed on each sub-population at respective nodes, and a calculation result is returned to a major node of Spark. The population with the fitness value is divided into a plurality of sub-populations which serve as the plurality of partitions of the RDD to be distributed to the plurality of nodes of the cluster again, each sub-population independently evolves at respective nodes, the best individuals in the different partitions of the RDD are collected when evolution meets an end condition, and the result is returned to the major node of Spark. The Spark-based parallel genetic algorithm provided by the invention utilizes a memory-based calculation model of Spark, the genetic algorithm is parallelized in the two aspects of fitness value calculation and genetic manipulation, thereby improving performance of the genetic algorithm.


Owner:HOHAI UNIV
Financial data analysis method and platform based on GPU acceleration and parallel genetic algorithm
InactiveCN106557979AReasonable analysisImprove work efficiencyFinanceGenetic algorithmsInformation resourceChromosome encoding
The invention discloses a financial data analysis method and a platform based on a GPU acceleration and parallel genetic algorithm. The method comprises steps: historical transaction data and real-time transaction data of variety prices are acquired, and related technical indexes are calculated; optimization is carried out on the related technical indexes; the selected technical index parameters are optimized, a chromosome code re-allocates a different length of bit string for each selected technical index; with the firm offer simulation operation total profit, the commission charge under the current transaction strategy, the input capital and the winning ratio and the claim ratio as parameters, the benefit condition and the risk aversion capability of the technical index combination selection and the profit stop strategy are evaluated comprehensively; a parallel genetic algorithm is used for adjusting the technical index combination and the technical index parameter combination; and the transaction strategy is generated. The method and the platform of the invention can handle huge and complicated information resource, the working efficiency is improved, and the data can be calculated more efficiently and timely; and the method and the platform can be applied to securities, futures, funds and the like, and an investor can be helped to make reasonable analysis in short time.


Owner:广州盛星元材料科技有限公司
Optimized design method and system for medicine logistics distribution path, and medium
PendingCN110852469AAvoid and Minimize ImpactOptimize delivery routeForecastingLogisticsGenetics algorithmsIndustrial engineering
The invention provides an optimized design method and a system for a medicine logistics distribution path and a medium. The optimization design method comprises the following steps: an algorithm framework design step: constructing a parallel genetic algorithm framework of a medicine logistics distribution path problem based on a MapReduce model; and a path optimization design step: according to the constructed supply chain design algorithm framework, carrying out medicine supply chain vehicle distribution path optimization design. The method and the system aim at the characteristics of a medicine supply chain distribution problem. According to the method, a reasonable technical method of medical service supply chain benefit distribution design, algorithm framework construction and medicalsupply chain vehicle distribution path optimization design is selected, and meanwhile, the influence of human factors in logistics distribution is avoided and reduced through the technical method, sothat the designed medical service supply chain better serves specific and objective requirements.


Owner:GUANGXI UNIV
Fluid machinery parallel simulation program process mapping method based on genetic algorithm
ActiveCN109241633AImprove execution efficiencyReduce communication overheadDesign optimisation/simulationMulti-objective optimisationDistance matrixMessage size
The invention discloses a fluid machinery parallel simulation program process mapping method based on genetic algorithm, includes such steps as linking process communication stake library when fluid mechanical parallel simulation program is compiled, capturing communication information of MPI communication during program running, and obtaining log file with message size and communication frequencyof inter-process transmission; Constructing a process communication mode matrix according to the communication log file; constructing a communication distance matrix of computing unit to test the communication cost of computing resources applied by users; Defining the communication overhead model of parallel simulation programs for fluid machinery; using hybrid parallel genetic algorithm to solvethe optimal process mapping strategy; according to the optimal process mapping strategy obtained from the hybrid parallel genetic algorithm, statically binding the MPI process to the specified compute node, and rerunning the fluid mechanical parallel simulation program.


Owner:XI AN JIAOTONG UNIV
Constrained optimization algorithm based on decomposition-parallel genetic algorithm
InactiveCN105955927AFast solutionComplex mathematical operationsGenetic algorithmsDecompositionMetapopulation
The invention discloses a constrained optimization algorithm based on a decomposition-parallel genetic algorithm. A problem for the constrained optimization algorithm is decomposed into Q subproblems and one conventional problem; the obtained Q subproblems are decomposed by the adoption of the genetic algorithm at first and iterative evolution is carried out in parallel till at least more than one half chromosomes in a population corresponding to various subproblems satisfy constraint conditions of the subproblems; the chromosomes satisfying the constraint conditions are selected from the subproblems and form multiple chromosomes in sequence as an initial population of a conventional population; then, parallel genetic algorithm iteration of the conventional problem and the subproblems is carried out; when a migration interval is achieved, forward migration and backward migration are respectively carried out; and when a migration number is up to a threshold value, the optimal chromosome is selected from the population of the conventional problem and used as a solution of a constraint optimization problem. By the adoption of the decomposition-parallel genetic algorithm, the optimal or nearly optimization solution of the constraint optimization problem can be solved rapidly.


Owner:UNIV OF ELECTRONIC SCI & TECH OF CHINA
Multi-target test optimization method based on series-parallel genetic algorithm
The invention discloses a multi-target test optimization method based on a series-parallel genetic algorithm. An optimized target and a constraint condition for test optimization of a plurality of electronic systems are determined based on needs; a genetic algorithm is performed by multiple times, wherein during the genetic algorithm performing process, a new population is obtained each time, individuals meeting the constraint condition are screened out and the screened individuals are added into an elite solution set, the number of dominated times of the individuals is obtained, and fitness values are calculated by using different ways by determining whether the individuals in the population belong to the elite solution set; optimal solution sets obtained by performing the genetic algorithm by multiple times are combined to form an individual in an initial population; the genetic algorithm is performed again to obtain an optimal solution set, wherein each individual is a testing optimization plan. According to the invention, on the basis of Pareto Optimality, the inventor designs a series-parallel genetic algorithm to obtain multiple kinds of test optimization plans meeting multiple targets, so that several kinds of test optimization plan alternatives are provided for the decision maker and different solutions are provided on different occasions.


Owner:UNIV OF ELECTRONICS SCI & TECH OF CHINA
AUV course angle control method based on PPGA self-adaptive optimization PID parameters
The invention provides an AUV (Autonomous Underwater Vehicle) course angle control method based on PPGA (Point-to-Point Graphics Array) self-adaptive optimization PID (Proportion Integration Differentiation) parameters. In order to solve the problems of slow response speed and uncertain parameters of the traditional PID method and the problems of easy premature phenomenon and slow convergence speed of the traditional genetic algorithm optimization, three optimal PID parameters in the control system are searched through a pseudo-parallel genetic algorithm so as to achieve course angle motion control of the AUV. The algorithm has good global optimization capability, and can find out an optimal solution in a feasible region through genetic optimization to obtain an optimal control scheme, thereby greatly improving the efficiency and precision of the controller.


Owner:NORTHWESTERN POLYTECHNICAL UNIV
Bi-phase medium parametric inversion method based on niche master-slave parallel genetic algorithm
InactiveCN103235879AImprove solution qualityImprove inversion accuracyGenetic modelsSpecial data processing applicationsPhacusPhases of clinical research
The invention relates to a bi-phase anisotropic medium reservoir parametric inversion method based on a niche master-slave parallel genetic algorithm. According to the method, the niche master-slave parallel genetic algorithm is used for solving bi-phase anisotropic medium reservoir parameters, the core ideology includes that a system comprises a master processor and a plurality of slave processors, the master processor monitors a whole population, at a fitness calculation stage, the master processor distributes calculation of the fitness to all slave processors, collects results after calculation and then performs operations such as niche elimination, selection, cross and variation to generate a new generation of population so as to finish one circulation, and the calculation efficiency of reservoir parametric inversion is improved greatly. According to the method, a concept of sharing degree is introduced in the reservoir parameter evolution solving process, substantial growth of some individuals are limited through adjustment of the fitness of each individual, niche evolution environments are created, and the capacity for solving multiple-peak reservoir parametric inversion optimization problems and the solving quality through the genetic algorithm are improved. The bi-phase medium parametric inversion method is widely applied to parametric inversion processes of oil and gas reservoirs.


Owner:CHINA NAT OFFSHORE OIL CORP +1
A key circuit cell location method based on embedded parallel genetic algorithm
ActiveCN109145411AShorten the design cycleHigh Reliability DesignSpecial data processing applicationsGenetic algorithmsComputer architectureIntegrated circuit layout
The invention relates to a key circuit unit positioning method based on an embedded parallel structure genetic algorithm, which belongs to the positioning technology field of key circuit units in integrated circuits. Specifically, the method includes: 1) network table analysis and initialization of related quantities; 2) constructing an initialization population oriented to the key circuit unit and initializing the current evolutionary algebraic variable j=1; 3) building a hall of fame library HG, and storing that b individual in each generation into the HG; 4) if i is greater than Nsm, go tostep 7), otherwise, going to step 5); 5) calculating the diversity div of the population; 6) calculating the key values of each circuit unit in the current HG circuit; 7) calculating the key values ofeach circuit unit in the LC; 8) arranging the key values obtained in the step 7 in descending order and outputting the corresponding circuit units. The invention is helpful for realizing the high reliable design of the circuit structure with less cost and shortening the design period of the circuit.


Owner:ZHEJIANG UNIV OF TECH
Deep learning parallel computing architecture method and hyper-parameter automatic configuration optimization thereof
PendingCN111709519APredictableShorten the timeNeural architecturesNeural learning methodsConcurrent computationConfiguration optimization
The invention discloses a deep learning parallel computing architecture method and hyper-parameter automatic configuration optimization thereof, and particularly relates to the field of deep learning.Firstly, a CNN is used for capturing spatial features of all places, and then an SRU is used for capturing sequential features of spatiotemporal data on the basis of the spatial features and used forregression prediction of the spatiotemporal data and hyper-parameter automatic configuration optimization of the spatiotemporal data; the invention has the beneficial effects that 1, regression prediction of spatio-temporal data is realized based on the SRU, so that parallel acceleration of the model to a certain extent is realized, and the time consumed by training and reasoning is reduced; 2, automatic configuration of the hyper-parameters of the model is realized based on a parallel genetic algorithm, so that manpower, energy and time consumed by hyper-parameter configuration are reduced,the hyper-parameters are more reasonable, and the prediction performance of the model is better.


Owner:HUNAN UNIV
Method and system using global and local catastrophes across sub-populations in parallel evolutionary computing
The invention provides a method and a system using global and local catastrophes across sub-populations in parallel evolutionary computing. A parallel genetic algorithm computing process tracks forward progress of a first sub-population across generations thereof. The first sub-population is one of a plurality of sub-populations that form a population of candidate solutions to an optimization problem. At a current generation of the first sub-population, it is determined that forward progress of the first sub-population fails a set of one or more forward progress criteria. In response to determining that the forward progress of the first sub-population fails the set of one or more forward progress criteria at the current generation, a local catastrophe is invoked on the current generation of the first sub-population. The first sub-population is re-populated after the local catastrophe is invoked. The first sub-population is re-established after re-populating while constraining migration to the first sub-population.


Owner:IBM CORP
Material bending process machining method and system based on cloud computing
ActiveCN110238244AAvoid the problem of inconsistent beatsSave time and costMetal working apparatusStrength of materialsComputer science
The invention discloses a material bending process machining method and system based on cloud computing. The material bending process machining method comprises the following steps of acquiring initialization parameters and online machining data of a machining material; under the machining condition of the initialization parameters, according to the online machining data, determining the degree of deviation; judging whether the degree of deviation is larger than the preset threshold value of the degree of deviation, and if yes, sending the initialization parameters and the online machining data to a cloud by industrial personal computers; by a could computed coarsness parallel genetic algorithm, determining material mechanical performance parameters according to the online machining data; determining bending paths according to the initialization parameters and the material mechanical performance parameters; sending the bending paths from the cloud to the industrial personal computers, and machining the machining material according to the bending paths; and if no, continuously machining the machining material by means of nominal mechanical performance parameters. By the adoption of the machining method and system, a lot of time can be saved, a lot of resource costs can be reduced, and the production efficiency of the product is greatly improved.


Owner:YANSHAN UNIV
System fault diagnosis method based on Malek model
The invention discloses a system fault diagnosis method based on a Malek model. The system fault diagnosis method comprises the following steps: indicating a fault-free node method to generate an initial population in the Malek model; calculating the fitness of individuals in the population and judging whether individuals with the fitness value of 1 are contained in the population or not; carrying out selecting operation and optimal storage; carrying out mutation operation; carrying out crossed operation and judging whether a t-diagnosable system is met; calculating the fitness value of the individuals in a new population and judging whether the individuals with the fitness value of 1 are contained in the new population. According to the diagnosis method, in virtue of the characteristics of parallel genetic algorithm and high global searching ability, the efficiency of positioning fault sets is improved, and meanwhile, the aspect of judging the accuracy of a target fault set is also superior to that of a traditional PMC model in combination with the Malek comparison model. The method is applied to system fault diagnosis problems, so that the target fault set can be found out more accurately and more quickly.


Owner:GUANGXI UNIV
Method for deducing operation states and parameters of adjacent hydropower stations by using observation data
PendingCN114154404AAvoiding Multiple Inference Result SituationsImprove search efficiencyData processing applicationsDesign optimisation/simulationPower stationAlgorithm
The invention discloses a method for inferring operation states and parameters of adjacent hydropower stations by utilizing observation data, which comprises the following steps of: firstly, establishing a reverse inference double-layer optimization model for the adjacent hydropower stations according to historical data measured and disclosed by the hydropower stations; secondly, reconstructing the double-layer optimization model by using a regularization method to avoid multiple inference results; and finally, aiming at the fact that the lower-layer model has a large-range infeasible region, solving the reconstructed model by using an improved parallel genetic algorithm which has an infeasible region avoiding function and retains elite. According to the method, the operation state and the operation parameters of the target power station can be deduced well, and compared with a traditional method, the solving method has the advantages of searching an optimal solution, avoiding an infeasible region and increasing the solving speed. According to the method, a new technical approach is provided for the hydropower station to reversely deduce the operation state and the operation parameters of the adjacent power stations, and a technical reference is provided for the cascade hydropower station to adapt to a new power system operation mode under the dual-carbon target.


Owner:DALIAN UNIV OF TECH
Unmanned aerial vehicle cluster attack task planning method based on hierarchical fusion framework
The invention provides an unmanned aerial vehicle cluster attack task planning method based on a hierarchical fusion framework. The method comprises the following steps: 1, importing unmanned aerial vehicle attack task scene information; 2, dividing the task targets into a plurality of task groups based on a K-means + + algorithm according to the position information of the striking targets; 3, assigning a task to each unmanned aerial vehicle based on a distributed parallel genetic algorithm, and distributing the unmanned aerial vehicle corresponding to each task target into a task group to which the task target belongs; 4, constructing a multi-agent reinforcement learning model, and regarding each unmanned aerial vehicle as an agent; 5, performing multi-agent reinforcement learning network training; and 6, repeating the step 5, and carrying out multiple rounds of confrontation between the red unmanned aerial vehicle and the blue unmanned aerial vehicle. Aiming at the problem of unmanned aerial vehicle cluster attack task planning in a complex battlefield environment, an efficient attack task planning model is constructed in combination with constraint conditions of unmanned aerial vehicle combat, and the pitch angle and the yaw angle of the unmanned aerial vehicle in each step are finally output, so that full-process planning simulation is realized.

Owner:BEIHANG UNIV
Chinese stock-oriented informed trading probability calculation method
InactiveCN108052487AMeasuring Information AsymmetrySolve the excessive calculationFinanceComplex mathematical operationsCalculation methodsFitness function
The invention discloses a Chinese stock-oriented informed trading probability calculation method. The method comprises the following steps of: aiming at features of the Chinese stock market, importingnew variables and constructing a Chinese stock market-oriented extension model for informed trading probability calculation; re-deducing a maximum likelihood function for parameter estimation and anextension formula for calculating informed trading probabilities according to the extension model; by adoption of a genetic algorithm, taking the deduced maximum likelihood function as a fitness function and accelerating operation of the genetic algorithm by using parallel equipment so as to obtain an optimal estimation result of a parameter; and calculating an extended informed trading probability according to the optimal parameter obtained by the genetic algorithm so as to obtain a generalized informed trading probability value suitable for Chinese conditions. According to the method, factors that investors consider to be located in bad situations in games when no message exists and the like are considered, so that information asymmetric condition of the Chinese stock market can be measured more accurately; and the parallel genetic algorithm is used for carrying out calculation, so that the calculation process can be accelerated.


Owner:SOUTH CHINA UNIV OF TECH
Modeling and dynamic distribution parameter confirmation method of electromagnetic transducer considering electro-magnetic-mechanical-acoustic coupling
The invention discloses an electromagnetic transducer modeling and dynamic distribution parameter confirmation method considering electro-magnetic-mechanical-acoustic coupling. The method comprises the following steps: constructing a dynamic multi-physical field distribution parameter model DPM of an electromagnetic transducer system; a PGA model optimization method based on a parallel genetic algorithm; the dynamic multi-physical field distribution parameter model DPM comprises the following steps: constructing an excitation loop equivalent model, wherein the excitation loop equivalent model comprises a plurality of excitation main loop units, a plurality of air gap magnetic flux leakage loop units and a plurality of permanent magnet loop units; and constructing a mechanical structure equivalent model, wherein the mechanical structure equivalent model comprises physical models such as a system radiation panel, a spring system and a rubber panel. According to the method, parameters of the DPM are optimized through the PGA algorithm, the performance efficiency of the electromagnetic transducer is improved, and a new method is provided for design of the electromagnetic transducer.

Owner:HUNAN UNIV