
Patents
Literature
159 results about "Hyperbolic tangent function" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
The hyperbolic tangent function can be represented using more general mathematical functions. As the ratio of the hyperbolic sine and cosine functions that are particular cases of the generalized hypergeometric, Bessel, Struve, and Mathieu functions, the hyperbolic tangent function can also be represented as ratios of those special functions.
Adaptive variable step-size LMS filter based on hyperbolic tangent function, filtering method thereof, and computer device
An adaptive variable step-size LMS filter based on a hyperbolic tangent function and its filtering method and computer equipment belong to the field of filter technology, and solve the problem that the LMS algorithm improved based on a nonlinear function requires too many manual adjustments of parameters and that the convergence speed and convergence accuracy of the traditional LMS algorithm cannot be satisfied simultaneously. The method of the present invention includes: determining the filter tap length and the number of iterations; initializing the filter parameters; obtaining the filter input signal vector; determining the instantaneous expected signal of the filter; obtaining the instantaneous output signal; obtaining the instantaneous error signal of the filter and the accumulated amount of the error signal based on the instantaneous output signal; obtaining the instantaneous step size using a step-size update formula based on a hyperbolic tangent function; and continuously iterating the filter tap weight coefficient vector to construct an LMS filter using the filter tap weight coefficient vector obtained after the number of iterations. The present invention is suitable for improving the performance of the LMS filter, and the filter of the present invention can be widely used in various signal processing fields.

Owner:HARBIN UNIV OF SCI & TECH +1
Multi-degree-of-freedom mechanical arm trajectory tracking method based on improved integral terminal sliding mode control
The invention relates to a mechanical arm trajectory tracking method based on improved integral terminal sliding mode control, and belongs to the technical field of robot control. According to the method, an integral sliding mode surface and a fast terminal sliding mode surface are combined to create a non-singular fast integral terminal sliding mode surface; an improved index reaching law is designed, and the buffeting problem existing in sliding mode control is weakened. The method comprises the following steps: S1, based on physical parameters of the mechanical arm, establishing a mechanical arm dynamic model by adopting a DH parameter method and a Lagrange dynamics principle; s2, constructing a non-singular fast integral terminal sliding mode surface for the dynamic system; s3, designing an improved reaching law fused with a hyperbolic tangent function; s4, performing trajectory planning by using a Cartesian space interpolation algorithm; s5, integrating the sliding mode surface, the improved reaching law and the dynamical model to derive a trajectory tracking control law; s6, constructing a closed-loop control model of the improved integral terminal sliding mode controller and the mechanical arm system; and S7, the control parameters are adjusted, and mechanical arm trajectory tracking is conducted. The control method serves as a controller to conduct trajectory tracking application on the six-degree-of-freedom mechanical arm. The result shows that on the premise of ensuring finite time convergence, the control method effectively eliminates the buffeting phenomenon of traditional sliding mode control, improves the trajectory tracking precision, has high robustness to external disturbance, and can realize high-precision tracking control of a mechanical arm end effector on a complex trajectory.

Owner:CHANGCHUN UNIV OF SCI & TECH
Single-bit direction of arrival estimation method and system with signal amplitude recovery function, terminal and storage medium
ActiveCN119846546ARadio wave direction/deviation determination systemsComplex mathematical operationsMinimization algorithmTarget signal
The invention discloses a single-bit direction of arrival estimation method and system with signal amplitude recovery, a terminal and a storage medium, and the method comprises the steps: obtaining each snapshot time signal from a signal source of a uniform linear array receiver, introducing a non-zero threshold value to carry out the single-bit quantization of each snapshot time signal, and obtaining a signal model; reconstructing the signal model, replacing a sign function of the reconstructed signal model with a smooth hyperbolic tangent function, and performing reconstruction to obtain a target signal model; based on the target signal model, constructing a single-bit DOA estimation optimization problem by using a truncated Frobenius norm and an L2, 0 norm, and converting the optimization problem into a target optimization problem by using a semi-quadratic technology; and solving a target optimization problem by using a near-end alternating minimization algorithm and a forward-backward splitting algorithm to obtain a signal source estimation direction, a signal source estimation number and a signal estimation amplitude. According to the method, the amplitude of the signal source is accurately estimated while the prior dependence on the number of the signal source is eliminated.


Owner:SHENZHEN UNIV
Thermocline identification method and system based on hyperbolic tangent function fitting
The invention belongs to the technical field of ocean temperature data identification, and discloses a thermocline identification method and system based on hyperbolic tangent function fitting. The method comprises the steps of data preparation and preprocessing; selecting a section range; fitting a curve; and determining a thermocline upper bound and a thermocline lower bound through a rolling function. According to the method, the hyperbolic tangent function is used for fitting the S-shaped characteristic curve of the temperature-depth profile, and the structure of the ocean thermocline is accurately described. Compared with a traditional Sigmoid function, the hyperbolic tangent function is better in performance when fitting a steep change area, and rapid temperature change of a thermocline central area can be caught more finely. According to the method, fitting parameters (amplitude, steep degree, central position and vertical offset) are optimized by adopting a trust region reflection algorithm, so that a fitting result is ensured to have higher precision and robustness, and the method is suitable for complex ocean profile data.

Owner:CHINA UNIV OF PETROLEUM (EAST CHINA)
Mechanical arm sliding mode control method
PendingCN119526389AGuaranteed accuracyReliable controlProgramme-controlled manipulatorDynamic modelsMotor control
The invention provides a mechanical arm sliding mode control method, and belongs to the technical field of robot control. A forward kinematics model of a mechanical arm which does not meet the Pieper rule is established; according to the forward kinematics model, a mechanical arm kinetic model is established by adopting a Lagrange method, an inverse kinematics equation corresponding to the forward kinematics model of the mechanical arm is solved by adopting an improved gradient descent method based on a Jacobian matrix, and a joint angle value of the solved mechanical arm is obtained; according to the joint angle error, a linear sliding mode surface is designed, sliding mode control is conducted on the joint angle, a sliding mode control law is obtained through construction according to a modeling estimated value in a mechanical arm dynamic model, and a sign function in the sliding mode control law is replaced with a hyperbolic tangent function. According to the method, the accuracy of inverse kinematics solution is ensured, the problem of moment jittering in sliding mode control is effectively reduced, and the mechanical arm which does not meet the Pieper rule is controlled to complete a high-precision motion control operation task.

Owner:SHENYANG UNIVERSITY OF TECHNOLOGY
Non-linear neural network equalizer for high-speed data channel
A data channel on an integrated circuit device includes a non-linear equalizer having as inputs digitized samples of signals on the data channel, decoding circuitry configured to determine from outputs of the non-linear equalizer a respective value of each of the signals, and adaptation circuitry configured to adapt parameters of the non-linear equalizer based on respective ones of the value. The non-linear equalizer includes a non-linear filter portion, and a front-end filter portion configured to reduce numbers of the inputs from the digitized samples. The non-linear equalizer may be a neural network equalizer, such as a multi-layer perceptron neural network equalizer, a reduced complexity multi-layer perceptron neural network equalizer, or a radial-basis function neural network equalizer. Alternatively, the non-linear equalizer may include a linear filter and a non-linear activation function, which may be a hyperbolic tangent function.

Owner:MARVELL ASIA PTE LTD
Single-bit image recovery method and device, terminal and medium
ActiveCN120355616AImage enhancementInternal combustion piston enginesImage QuantificationQuantization (image processing)
The invention discloses a single-bit image recovery method and device, a terminal and a medium, and relates to the field of image processing. The method comprises the following steps: performing single-bit quantization on a to-be-recovered image by adopting a non-zero quantization threshold, and determining an initial image quantization model; replacing a sign function in the initial image quantization model with a smooth hyperbolic tangent function, performing low-rank matrix decomposition on the to-be-recovered image, and determining a target image quantization model; determining an initial optimization model according to the truncated least square function and the target image quantization model; a semi-quadratic minimization method is adopted to convert the initial optimization model, and a target optimization model is determined; solving the target optimization model by adopting a near-end block coordinate descent algorithm to obtain each low-dimension sub-matrix and a noise matrix; and determining a reconstructed image by using each low-dimensional sub-matrix. The problem that in the prior art, quantization noise cannot be effectively restrained, and therefore image restoration precision is affected is effectively solved.

Owner:SHENZHEN UNIV
Fractional order memristor Hopfield neural network circuit implementation method based on FPGA
ActiveCN119272828AHigh precisionextended cycleArchitecture with single central processing unitPhysical realisationSignal onTerm memory
The invention relates to an FPGA (Field Programmable Gate Array)-based fractional order memristor Hopfield neural network circuit implementation method, which adopts a Grunwald-Letnikov fractional order derivative definition and short-term memory principle to finish the implementation of an FPGA circuit of a fractional order memristor Hopfield model through a multi-segment linear fitting hyperbolic tangent function. The method comprises the specific steps of processing a fractional order integral and a hyperbolic tangent function, compiling through Verilog codes and simulating in Xilinx ISE. According to the method, the short-time memory principle and the resource-efficient fitting algorithm are combined, high-precision periodic and chaotic signals can be generated on the FPGA, and the method has a wide application prospect.

Owner:NANJING NORMAL UNIVERSITY
Intelligent control system for old-age care robot based on Internet of Things
The invention relates to the technical field of intelligent control, in particular to an internet-of-things-based old-age care robot intelligent control system, which comprises a multi-mode sensing layer, a safety decision center, an execution driving module, a voice interaction optimization module and an internet-of-things communication module. According to the method, force sense data such as contact force of the mechanical arm, voice data such as voices of old people and view data such as obstacles are collected in real time through a multi-mode sensing layer, a displacement force coupling risk value is calculated through a hyperbolic tangent function coupling model of a safety decision center, and a deviation angle risk value is analyzed and calculated through an improved Lyapunov index spectrum; a total risk value is generated through fusion and is scheduled according to hierarchical intervals, mechanical operation, old people behaviors and environmental risks can be dynamically avoided, and the use safety is remarkably improved; through sub-ambiguity quantitative analysis, comprehensive ambiguity evaluation and intention correction of the voice interaction optimization module, instruction intention is optimized in combination with multi-modal data, the problem of fuzzy voice recognition of old people is effectively solved, and interaction accuracy and response efficiency are greatly improved.

Owner:WEISEN POWER (WUXI) TECH CO LTD
Hyperbolic continuous robust control method for vertical system of special vehicle launching tube
The invention discloses a hyperbolic continuous robust control method for a vertical system of a special vehicle launching tube, which is based on the characteristic of external interference suppression in traditional sliding mode control, combines the smooth characteristic of a hyperbolic tangent function, and achieves the robust control of the vertical system of the launching tube under the condition that strong uncertainty nonlinearity and strong external interference exist in the system. The system flutter phenomenon can be prevented while nonlinearity is compensated and interference is suppressed, the control precision is effectively improved, the error convergence time is shortened, the tracking performance is improved, and finally an exponential stable error convergence result is obtained. Compared with the prior art, the control method disclosed by the invention effectively solves the problems caused by strong nonlinearity and strong external interference of the vertical stabilization system of the special vehicle launching tube, so that the control precision of the whole system is improved, and good tracking performance is obtained.


Owner:NANJING UNIV OF SCI & TECH
Semiconductor nonlinear output junction capacitance measurement method based on fitting iteration
The invention relates to the technical field of semiconductor device measurement, and provides a semiconductor nonlinear output junction capacitance measurement method based on fitting iteration, and the method comprises the steps: firstly building a junction capacitance extraction circuit, collecting the turn-off transient waveform of a to-be-measured device through a test platform, extracting the oscillation frequency fexp through fast Fourier transform, and carrying out the measurement of the to-be-measured device; based on the relation between the oscillation frequency and the junction capacitance and parasitic parameters, the initial junction capacitance Coss is reversely deduced; then, fitting is carried out by adopting a hyperbolic tangent function, fitting parameters are optimized through a least square method, a preliminary junction capacitance Coss-test voltage udc relation curve under different voltage grades is obtained, an oscillation frequency simulation circuit is further built, simulation frequency fm is obtained, fm is compared with fexp, if deviation exists, the fitting curve is adjusted and iterative optimization is carried out, and the test voltage udc relation curve of the junction capacitance under different voltage grades is obtained. And ending until the error of two adjacent rounds of fitting results is lower than a set error threshold value, thereby obtaining a final accurate junction capacitance Coss-test voltage udc relation curve.

Owner:KUNMING 705 TECH DEV CO LTD +1
Four-rotor aircraft trajectory tracking control method based on improved event triggering mechanism
ActiveCN119759074AVehicle position/course/altitude controlPosition/direction controlFly controlFlight vehicle
The invention discloses a four-rotor aircraft trajectory tracking control method based on an improved event triggering mechanism. In a four-rotor aircraft trajectory tracking task, an anti-saturation auxiliary system is firstly designed to solve the problem of actuator input saturation of a four-rotor aircraft. The saturation phenomenon is modeled and compensated in advance, so that the influence of the problem on the control performance of the system is reduced. And secondly, through combination of a self-adaptive gain item and a fuzzy controller, a sliding mode reaching law hyperbolic tangent function coefficient is softened, a chattering phenomenon existing in sliding mode control is further inhibited, and the control performance is improved. Finally, an improved event triggering mechanism is designed at an actuator end, a self-adaptive triggering threshold value is introduced, redundant transmission is avoided, dynamic adaptability is enhanced, and communication resources are further saved. According to the method provided by the invention, the requirement of green flight control is met while the control performance of the system is improved.

Owner:NANJING UNIV OF AERONAUTICS & ASTRONAUTICS
Three-dimensional medical image segmentation method
The invention relates to the technical field of image processing, and discloses a three-dimensional medical image segmentation method, which comprises the following steps: acquiring two prediction segmentation probability graphs of each sample based on two parallel sub-networks of a dual-network segmentation model, and calculating a soft pseudo label of an unlabeled sample; utilizing a distance regression head and a hyperbolic tangent function to obtain two prediction symbol distance fields of each sample based on the decoding feature map; calculating segmentation loss and regression loss of each labeled sample, and adding the segmentation loss and the regression loss to obtain supervision loss; calculating the pseudo label consistency loss and the symbol distance consistency loss of each unlabeled sample, and adding the pseudo label consistency loss and the symbol distance consistency loss to obtain consistency loss; optimizing the dual-network segmentation model under the joint constraint of supervision loss and consistency loss; and obtaining an input segmentation result of the to-be-segmented three-dimensional medical image by using the trained dual-network segmentation model. According to the method, the problem of class imbalance in the three-dimensional medical image is effectively relieved, and the segmentation precision of the weak edge region is improved.

Owner:SUZHOU UNIV
Hot rolled steel strip surface defect detection method based on target detection
The invention provides a hot rolled steel strip surface defect detection method based on target detection, and aims to solve the problems of difficulty in multi-scale small target recognition, insufficient feature fusion and complex background interference in hot rolled steel strip surface defect detection. Extracting multi-scale defect features by using wavelet convolution through decomposition, convolution and reconstruction processes; multi-scale features are adaptively fused based on channels and space attention through a dynamic feature fusion module (DFF); a dynamic hyperbolic tangent function (DyT) is used to replace a normalization layer to dynamically adjust the input range and compress extreme values to reduce the amount of calculation. The method has the effects of high detection average precision (mAP), low missing report rate and remarkably reduced calculation complexity, effectively improves the efficiency and reliability of identifying the surface defects of the hot rolled steel strip in a complex industrial environment, and is suitable for intelligent steel manufacturing quality control.


Owner:SPECIAL EQUIP SAFETY SUPERVISION INSPECTION INST OF JIANGSU PROVINCE
Mechanical arm self-adaptive sliding mode control method based on disturbance observer
The invention discloses a mechanical arm self-adaptive sliding mode control method based on a disturbance observer, and relates to the technical field of mechanical arm control, and the mechanical arm self-adaptive sliding mode control method comprises the following steps: constructing an initial dynamic model based on a Lagrange equation; constructing a simplified two-degree-of-freedom rigid mechanical arm dynamic model based on the initial dynamic model; designing a novel reaching law fusing the advantages of an exponential reaching law and a power reaching law, and combining a hyperbolic tangent function to replace a sign function to construct a sliding mode surface; designing a nonlinear disturbance observer, estimating the total disturbance of the system in real time, carrying out feed-forward compensation, and bringing the composite disturbance influence into a control law; designing a control law and an adaptive law of the mechanical arm through a Lyapun function; the stability of the system is analyzed through a Lyapunov function, tracking errors are proved to be asymptotically converged, and the method is used for ensuring the reliability and stability of the control system. According to the method, the disturbance observer and the self-adaptive sliding mode control strategy are combined, and the control precision and robustness of the mechanical arm when external disturbance and model uncertainty exist are effectively improved.

Owner:WUXI XINENG REAL ESTATE MANAGEMENT CO LTD
Permanent magnet synchronous motor control method and system of improved sliding mode observer
PendingCN119448843Areduce jitterVerify feasibilityElectronic commutation motor controlElectric motor controlLow-pass filterPermanent magnet synchronous motor
The invention provides an improved sliding-mode observer for permanent magnet synchronous motor position sensorless control. A traditional sliding-mode observer can cause a jitter phenomenon of observation information in motor control. According to the method, the control equation of the sliding-mode observer is redesigned, the adaptive rate is combined, and a low-pass filter is replaced, so that the estimation precision of the back electromotive force is improved. A hyperbolic tangent function is used to replace a sign function to alleviate the jitter problem of the observer, and a phase-locked loop technology is used to replace an arc tangent function to reduce estimation errors and phase delay. The feasibility of the control system is verified by building a system simulation model based on a static coordinate system in MATLAB / Simulink. A simulation result shows that the control system reduces the rotor speed error and the rotor position error, so that the control performance and the stability of the permanent magnet synchronous motor are improved.

Owner:JIANGSU UNIV OF TECH
Multi-unmanned aerial vehicle optimal game limited acceleration reinforcement learning control method and device
The invention provides a multi-unmanned aerial vehicle optimal game limited accelerated reinforcement learning control method and device, and relates to the technical field of accelerated reinforcement learning. The method comprises the following steps: constructing an evaluation neural network, and approaching a performance index function of a hyperbolic tangent function and a game neighbor item, the optimal limited control input of the unmanned aerial vehicle and the limited control input of the unmanned aerial vehicle under the worst condition; based on the input parameters, constructing a Hamilton-Jacobian error equation; through an error equation, constructing a summation square error which contains current information and past information and is provided with adjusting parameters; designing a weight updating law for evaluating the neural network; calculating the weight of the next iteration according to a weight updating law; and solving an error between two adjacent iteration weights, comparing the error with a preset threshold value, if the error is smaller than the preset threshold value, stopping iteration, and outputting a solution approaching the optimal game consistency control problem of the distributed unmanned aerial vehicle system. According to the invention, the cooperation efficiency between the unmanned aerial vehicles can be improved.

Owner:UNIV OF SCI & TECH BEIJING
FPGA-technology-based neuron circuit implementation method using multi-segment linear fitting
PCT designated stage expiredWO2025035585A1Architecture with single central processing unitEnergy efficient computingNeuron circuitNeuron
Disclosed in the present invention is an FPGA-technology-based neuron circuit implementation method using multi-segment linear fitting. The method comprises: first, on the basis of the parity and value range of a hyperbolic tangent function in combination with a multi-segment linear fitting algorithm, processing the function, then designing a neuron circuit module for solution, performing simulation verification of implementability by means of software, and finally burning a program into an FPGA to observe consistency with the simulation verification by means of an oscilloscope. In the present invention, high-precision periodic signals and chaotic signals are generated on an FPGA by using a high-speed and high-precision multi-segment linear fitting algorithm with low resource consumption, so that abnormal discharge behaviors of an FHN neuron circuit can be more visually observed on hardware devices. The present invention provides a new method for using an FPGA to generate improved FHN abnormal discharge signals including a hyperbolic tangent function, the principle of implementing the hyperbolic tangent function by means of the FPGA can be extended to other complex functions, such as an exponential function, a logarithmic function and a transcendental function, and the present invention can be widely applied to the disciplines and fields of nonlinear neurons, intelligent control, etc.
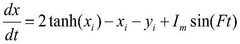
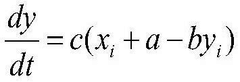
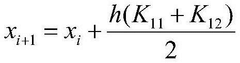
Owner:NANJING NORMAL UNIVERSITY
Cooperative anti-swing control method and system for double ship cranes based on preset performance
The invention provides a cooperative anti-swing control method and system for double marine cranes based on preset performance, and relates to the technical field of crane control. Comprising the following steps: establishing a marine crane dynamical model considering double-ship rolling disturbance by using a Lagrange method; determining a drivable variable, and establishing a tracking error of the drivable variable; introducing an exponential preset performance function, constraining the convergence rate, overshoot and steady-state value of the tracking error, and converting the constrained tracking error into an unconstrained variable by using a hyperbolic tangent function; a performance index function considering tracking errors and energy consumption is constructed, a Hamiltonian equation minimization performance index function is constructed, the Hamiltonian equation is solved through a reinforcement learning algorithm, and the optimal control rate is obtained. According to the invention, the convergence speed of the error of the system variable is limited in a preset interval, the steady-state and transient-state performance of error convergence is improved, and accurate control and anti-swing of the load are realized.

Owner:SHANDONG UNIV +2
Non-autoregressive sign language generation method based on KAN enhancement, medium and equipment
The invention discloses a non-autoregressive sign language generation method based on KAN enhancement, a medium and equipment, and belongs to the technical field of computer vision technologies. The invention aims to solve the problems of insufficient action details and poor action time sequence coherence of the generated sign language video caused by continuous propagation of local errors along with the increase of the sequence length when the sign language long sequence is generated in the existing method for generating the sign language video based on the autoregression architecture. According to the method, a Transform model of a non-autoregression mechanism is used, a space-time self-attention mechanism is used for replacing a multi-head attention mechanism, a KAN network is used for replacing an MLP layer, a dynamic hyperbolic tangent function is used for replacing layer normalization of a traditional encoder and a traditional decoder, and sign language skeleton sequences are generated in parallel; and performing kinematics optimization and frame-by-frame rendering on the generated sign language skeleton sequence to obtain a sign language video with sufficient detail display and coherent actions. The method is mainly used for generating sign language videos from text data.

Owner:JIAMUSI UNIVERSITY
Video coding method based on multi-domain perceptual feature fusion
The invention discloses a video coding method based on multi-domain perception feature fusion, and belongs to the technical field of image communication. The method comprises the following steps: extracting perception features of a space domain, a time domain and a frequency domain from an input video frame sequence; normalizing the multi-domain sensing features, and generating a sensing importance factor for each coding unit through a dynamic fusion weight mechanism; constructing perceptual distortion evaluation based on perceptual importance factors, replacing a traditional rate distortion objective function, and guiding code rate distribution of coding units; and according to the perception importance factor, performing nonlinear mapping by using a hyperbolic tangent function, calculating to obtain a coding unit level quantization parameter adjustment amount, and obtaining a final quantization parameter in combination with the basic quantization parameter, thereby realizing adaptive rate distortion optimization. According to the method, the visual sensitive area can be accurately identified, and the code rate is remarkably reduced while the subjective visual quality is guaranteed.

Owner:SHIJIAZHUANG TIEDAO UNIV
Dual face counterfeiting active defense method based on frequency limitation
The invention discloses a dual face counterfeiting active defense method based on frequency limitation, and the method is characterized in that the method comprises the following steps: S1, constructing an encoder-decoder structure; s2, image preprocessing and watermark information preprocessing; s3, converting an image domain; s4, performing frequency limitation and a mask mechanism; s5, adding resistance disturbance; a hyperbolic tangent function is used as a nonlinear disturbance method to simulate noise interference. The invention relates to the technical field of image processing, in particular to a dual face counterfeiting active defense method based on frequency limitation. The technical problem to be solved by the invention is to provide a dual face forgery active defense method based on frequency limitation, which combines an information hiding technology and a generative adversarial network to simultaneously embed watermark information used for tracing and disturbance information used for disturbing and tampering a model into a face image to be protected. The advantages of the two active defense methods are combined to achieve a more perfect face defense effect.

Owner:QILU UNIVERSITY OF TECHNOLOGY (SHANDONG ACADEMY OF SCIENCES)
Design and application method of sliding mode deadbeat reaching law
PendingCN120566968AElectronic commutation motor controlElectric motor controlElectrical engineering technologyMathematical model
The invention provides a design and application method of a sliding-mode deadbeat reaching law, and relates to the technical field of electrical engineering, and the method comprises the steps: designing a sliding-mode deadbeat reaching law SMDRL, designing a control strategy through a deadbeat control principle, defining a state change law on a sliding-mode surface through a sign function, and achieving the design of the sliding-mode deadbeat reaching law SMDRL. It is ensured that the system state converges to the sliding mode surface at the fastest speed in a control period; an improved sliding mode deadbeat reaching law ISMDRL is designed, a traditional sign function is replaced with a hyperbolic tangent function, and parameters of the hyperbolic tangent function are adjusted according to the system state; the SMDRL and the ISMDRL are applied to a speed driving system of a permanent magnet synchronous motor (PMSM), and the speed driving system comprises a PMSM mathematical model, a sliding mode speed controller with a speed disturbance observer and model prediction current control. The SMDRL is introduced from the traditional sliding mode reaching law for the first time through theoretical derivation, the convergence time of the SMDRL is the shortest, and the SMDRL is applied to a permanent magnet synchronous motor speed driving system.

Owner:NORTH CHINA UNIVERSITY OF TECHNOLOGY
Mathematical modeling AI prediction system in financial risk assessment
The invention discloses a mathematical modeling AI prediction system in financial risk assessment, which relates to the field of financial data processing and comprises a feature principal component extraction module, a compensation alignment execution module, a momentum regulation and control decision module, a gradient direction optimization module and a risk assessment output module. According to the method, principal components are extracted through covariance matrix decomposition of the qualification-debt ratio and the cash flow fluctuation ratio, feature redundancy is eliminated, the core risk characterization efficiency is improved, a cross-market compensation matrix of transaction frequency and price fluctuation is constructed in combination with SVD and cosine similarity, and the model environment adaptability is enhanced. And analyzing momentum attenuation by adopting a dynamic sliding window of a second derivative matrix eigenvalue ratio, and establishing a regulation and control mechanism to suppress gradient oscillation. Orthogonal interference of historical momentum vectors is eliminated through Schmidt orthogonalization projection, and the accuracy of the gradient optimization direction is guaranteed. And converting abstract numerical values into interpretable risk level classification by using a hyperbolic tangent function in combination with credit rating interval mapping.

Owner:YANAN VOCATIONAL & TECHN COLLEGE
Infrared image segmentation method based on local region self-organizing mapping algorithm
The application discloses an infrared image segmentation method based on a local region self-organizing mapping algorithm, which comprises the following steps: firstly, a local region self-organizing mapping algorithm is designed, a plurality of feature bias fields are extracted by moving a local sliding window before iterative evolution of a level set, and a plurality of feature local data driving terms are constructed under a multiplicative bias field model framework; secondly, a plurality of feature global data driving terms are calculated, and a plurality of feature hybrid data driving terms are constructed through an adaptive weight function; then, an adaptive regularization function is used to regularize an energy value range of the plurality of feature hybrid data driving terms, and an initial level set is driven to perform iterative evolution; then, in the iterative process of the level set, a hyperbolic tangent function is used to keep the level set in the iterative evolution, and a symbol rule feature of positive outside and negative inside and a distance rule feature with a modulus value of 1 are kept; meanwhile, a mean filter template is used to continuously smooth the level set and eliminate redundant non-boundary contour lines; finally, a gradient descent method is used to continuously iteratively solve a minimum value of an energy function until a convergence criterion of the level set is reached or a maximum iteration number is reached, and then the method is stopped, at this time, a position of a zero level set is output, and image segmentation is completed. The local region self-organizing mapping algorithm can accurately mine a foreground contour from an infrared image, and has good segmentation speed and precision.

Owner:NANJING UNIV OF SCI & TECH
Single-bit image restoration method, device, terminal and medium
ActiveCN120355616BImage enhancementInternal combustion piston enginesImage QuantificationQuantization (image processing)
The present invention discloses a single-bit image restoration method, device, terminal, and medium, relating to the field of image processing. The method employs a non-zero quantization threshold to single-bit quantize an image to be restored, determining an initial image quantization model; employs a smooth hyperbolic tangent function to replace the sign function in the initial image quantization model, and performs low-rank matrix decomposition on the image to be restored, determining a target image quantization model; determines an initial optimization model based on a truncated least squares function and the target image quantization model; employs a semi-quadratic minimization method to transform the initial optimization model and determine a target optimization model; employs a proximal block coordinate descent algorithm to solve the target optimization model to obtain low-dimensional submatrices and a noise matrix; and utilizes the low-dimensional submatrices to determine a reconstructed image. This method effectively addresses the problem that prior art cannot effectively suppress quantization noise, thereby affecting image restoration accuracy.


Owner:SHENZHEN UNIV
A method and device for quantizing model parameters of convolutional neural network and related devices
The present application discloses a method for quantizing model parameters of a convolutional neural network, including: obtaining a data set for a digital classification task; constructing a convolutional neural network for the digital classification task; using the data set to train the convolutional neural network, and the trained convolutional neural network is used to perform the digital classification task; wherein, during the forward propagation process of the quantized convolution layer, the model parameters are quantized based on a sign function; the model parameters include weights and activation values; during the backward propagation process of the quantized convolution layer, the model parameters are quantized based on a parameterized hyperbolic tangent function; wherein the parameters in the hyperbolic tangent function are determined based on the data distribution of the model parameters of the quantized convolution layer, and the present application can improve the model accuracy of digital classification. The present application also discloses a device for quantizing model parameters of a convolutional neural network, a computer-readable storage medium, and an electronic device, which have the above beneficial effects.

Owner:INSPUR (BEIJING) ELECTRONICS INFORMATION IND CO LTD
A training method and device of a current density distribution identification model
ActiveCN120671351BCurrent density measurementsDesign optimisation/simulationComputational physicsSeries expansion
The application provides a training method and device of a current density distribution identification model, the method comprising: inputting a plurality of sampling source points into the current density distribution identification model, and obtaining a loss function in the current density distribution identification model, which is constructed based on a current density distribution function and an electric field integral equation; wherein the loss function comprises a hyperbolic tangent function, a derivative of the hyperbolic tangent function and a product of the Green function; performing series expansion on the hyperbolic tangent function in the loss function, and extracting singular terms from the electric field integral equation in the series expanded loss function to obtain a plurality of singular integrals; performing inner integral calculation and outer integral calculation on each high-order singular integral in the singular integrals to determine the current density distribution function corresponding to the minimum value of the loss function on all sampling source points. The application can quickly solve the singular integrals comprising the hyperbolic tangent function, the derivative of the hyperbolic tangent function and the product of the Green function to obtain the current density distribution function.

Owner:INST OF APPLIED PHYSICS & COMPUTATIONAL MATHEMATICS
Industrial manipulator anti-saturation tracking control method based on extended state observer
The invention discloses an industrial manipulator anti-saturation tracking control method based on an extended state observer, and belongs to the field of industrial manipulator automatic moving trajectory control, and the method comprises the following steps: based on a dynamic model of an industrial manipulator, carrying out modeling processing on the output saturation characteristic of an execution mechanism by adopting a hyperbolic tangent function, and obtaining an output saturation characteristic of the execution mechanism; obtaining a kinetic model subjected to anti-saturation processing; designing an extended state observer with a semi-global consistent final stability characteristic on the basis of the dynamic model subjected to anti-saturation processing, and outputting an unknown function estimation value on the basis of the extended state observer; and based on an unknown function estimation value, a recursive anti-saturation control signal is designed by adopting a dynamic surface control architecture, and accurate tracking control of the industrial manipulator is realized. The design of the extended state observer not only can estimate the unknown dynamic state in the controlled system in real time, but also saves the calculation overhead caused by training the weight of the neural network, so that the execution and deployment efficiency is relatively high.

Owner:RES INST OF HIGHWAY MINIST OF TRANSPORT +1
An improved sliding mode active disturbance rejection control method and system for a vehicle shimmy system based on an electromagnetic linear actuator
This invention provides an improved sliding mode active disturbance rejection control (ADRC) method and system for an automotive shimmy system based on an electromagnetic linear actuator. Addressing the system's strong nonlinear characteristics and unknown external disturbances, a mathematical model of the automotive shimmy system based on the electromagnetic linear actuator is established. A nonlinear tracking differentiator is constructed to process the desired input signal of the wheel shimmy angle, rationally arrange the transient process, and synchronously extract the differential signal of the desired signal. A continuous and smooth Ifal function is constructed based on trigonometric sine and inverse proportional functions, and a novel extended state observer is designed to estimate the system's internal and external disturbances in real time. A super-helical sliding mode control law based on the hyperbolic tangent function is designed to replace the error feedback control law in the traditional ADRC, outputting a control voltage. This invention effectively estimates and compensates for the impact of vehicle state parameter changes, model uncertainties, and external disturbances on system stability, improving dynamic performance and control accuracy, and exhibiting good robustness and anti-interference capabilities.

Owner:JIANGSU UNIV