
Patents
Literature
125 results about "Sea turtle" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Sea turtles (superfamily Chelonioidea), sometimes called marine turtles, are reptiles of the order Testudines and of the suborder Cryptodira. The seven existing species of sea turtles are the green sea turtle, loggerhead sea turtle, Kemp's ridley sea turtle, olive ridley sea turtle, hawksbill sea turtle, flatback sea turtle, and leatherback sea turtle.
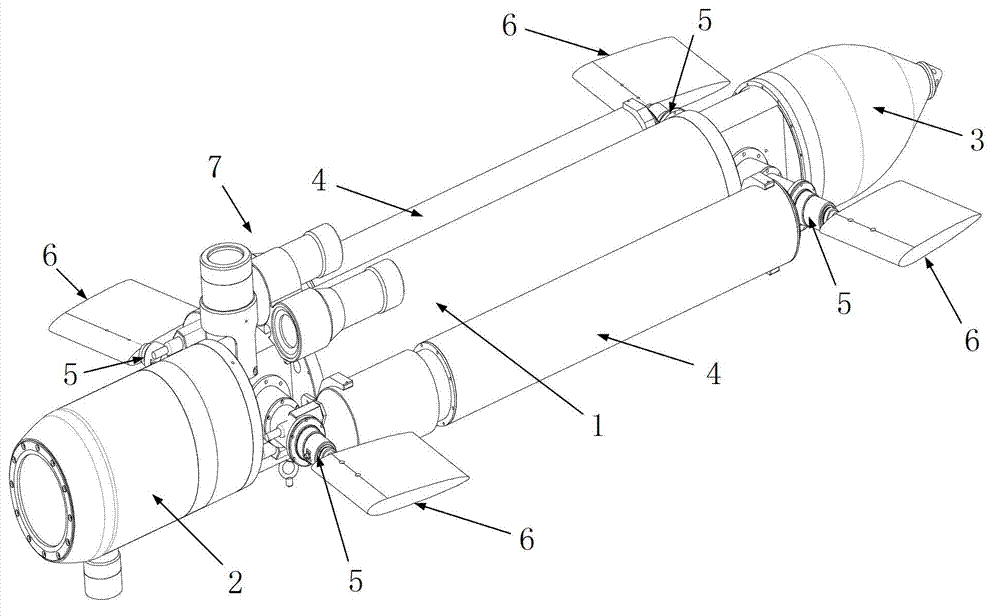
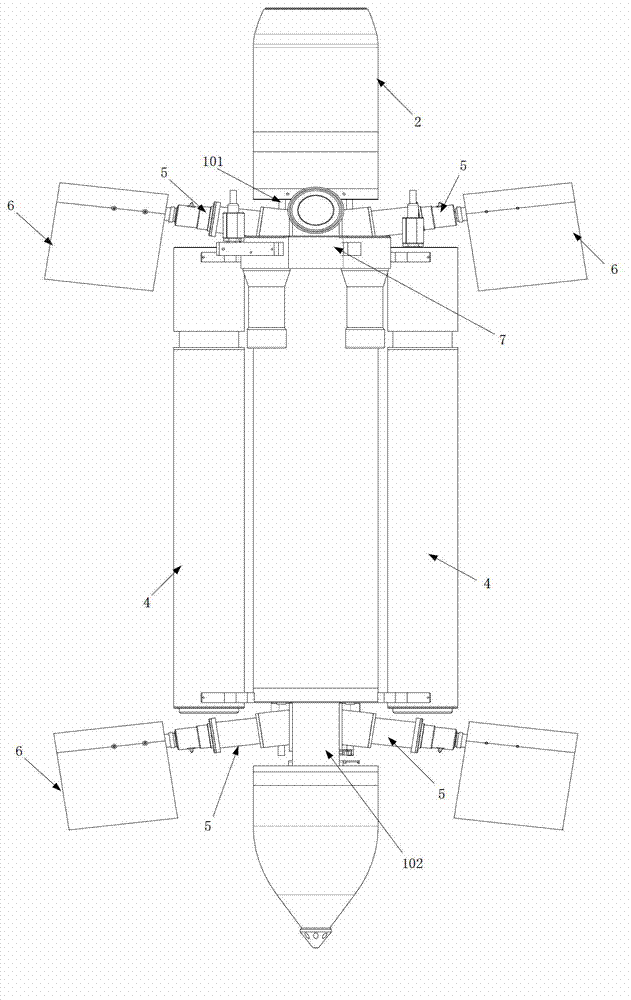
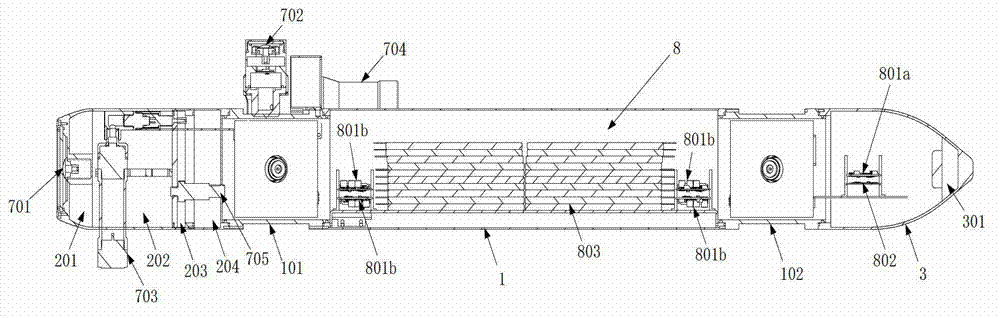
Sea turtle four-fin flapping imitating type autonomous underwater robot
InactiveCN103085955AControl thrust directionImprove mobilityPropulsive elements of non-rotary typeUnderwater vesselsOcean bottomFull view
The invention discloses a sea turtle four-fin flapping imitating type autonomous underwater robot which comprises a body part, a head part and a tail part. The front side and the back side of the body part are connected with moving fins through fin limbs. Each flapping fin is driven and controlled independently. The head part and the tail part are respectively arranged in front of and behind the body part. Full-view fisheye lenses for acquiring front images and upper images are respectively arranged in the head part and on the body part. A height measuring sonar for acquiring height and a pressure sensor for acquiring depth are arranged in the head part. A global position system (GPS) antenna for locating is arranged in the tail part, and accordingly water area conditions in front and on the upper portion can be monitored in real time, height data between the robot and the seabed can be measured in real time, and obstacle conditions and the like in front can be monitored. The underwater robot is further provided with an attitude and heading reference system (AHRS), self attitude can be sensed in real time, active control of attitude and heading can be achieved, and the underwater robot has the advantages that a driving mode of sea turtle four-fin flapping imitating pushing is used, maneuverability is good, noise is low, structure is simple, and implementation is simple.
Owner:BEIHANG UNIV
Dehooking device with slidable bite sleeve
A dehooking device with a slidable bite sleeve having a rod (1) with a spiral looped hook removal end (2), handle (3), and a slidable bite sleeve (4). The rod (1) is preferably made of steel while the bite sleeve (4) is preferably made of plastic. The method of use of the present invention will permit the removal of a hook from a fish (9), turtle, or other sea creature's mouth while being able to maintain the mouth in a somewhat open position. Furthermore, the use of this invention protects the mouth of the fish, turtle, or other sea creature by shielding the hook during the removal process.


Owner:OTSAR U C D 9 15 00
Method of lighting for protecting sea turtles
A method of lighting to protect sea turtles comprises providing in a housing both a white light source, for example a low-voltage incandescent source, and a red LED source that is visible to humans but that does not interfere with the normal nesting and hatching behavior of sea turtles, and selectively energizing the latter source during turtle nesting season.


Owner:BEEMAN HLDG INC
Sea turtle-like underwater robot
InactiveCN107140163ASimple mechanical structure designEasy to processPropulsive elements of non-rotary typeFlapping wingMarine engineering
The invention provides an underwater robot imitating a sea turtle. One end of the sealing box is provided with a double-layer bracket, and the lower end of the lower bracket of the double-layer bracket is symmetrically installed with two main steering gears. The output end of each main steering gear is connected to the first A steering gear plate, two rotating shafts are symmetrically arranged on the upper bracket of the double-layer bracket, and the end of each rotating shaft is respectively provided with a second steering gear plate, and between the second steering gear plate and the first steering gear plate Auxiliary steering gear is provided, the output end of each auxiliary steering gear is connected with a third steering gear disc, each third steering gear disc is provided with a first connecting rod, and the other end of the sealed box is symmetrically provided with two steering gears Each steering gear bracket is equipped with a driving steering gear, and the output end of each driving steering gear is equipped with a fourth steering gear plate, and each fourth steering gear plate is provided with a second connecting rod, and the first connecting rod The end of the second connecting rod is provided with a hydrofoil imitating the fin of a sea turtle. The invention can realize the flapping movement of the hydrofoil imitating the sea turtle's fin, and is beneficial to improve the service life and maneuverability of the device.

Owner:HARBIN ENG UNIV
Harrison hurricane pulse and tsunami duty protective seawalls (HHTPS) which are constructed of permanent, heavily steel rebar reinforced concrete, with the seawall foundations driven down to ground rock refusal every 30 feet, or less or more, of seawall horizontal length
Harrison hurricane pulse and tsunami duty protective seawalls (HHTPS) are constructed of permanent, heavily steel rebar reinforced concrete, with multiple seawall foundations driven down to ground rock refusal every 30 feet and are normally 140 feet high. These seawalls shall protect many areas that are subject to flooding and / or massive storm pulses such as hurricane Katrina. These seawalls shall protect areas at risk of tsunami waves. Tsunamis are caused by undersea earthquakes, undersea volcanoes, etc. that produce a huge destructive sea wave called a tsunami. These seawalls have the strength on top to allow construction of roads for vehicular traffic. These seawalls protect such locations as New Orleans, La. and adjacent Gulf Coast areas, the Mississippi Gulf Coast, the Texas Gulf Coast and others. These seawalls shall protect such places as Indonesia, and other places that are subject to a tsunami. These seawalls allow sandy or other beaches for humans and sea animals (such as sea turtles). These seawalls function off shore over water to protect small islands from a huge storm pulse or tsunami.


Owner:HARRISON WILBUR ERNEST JR
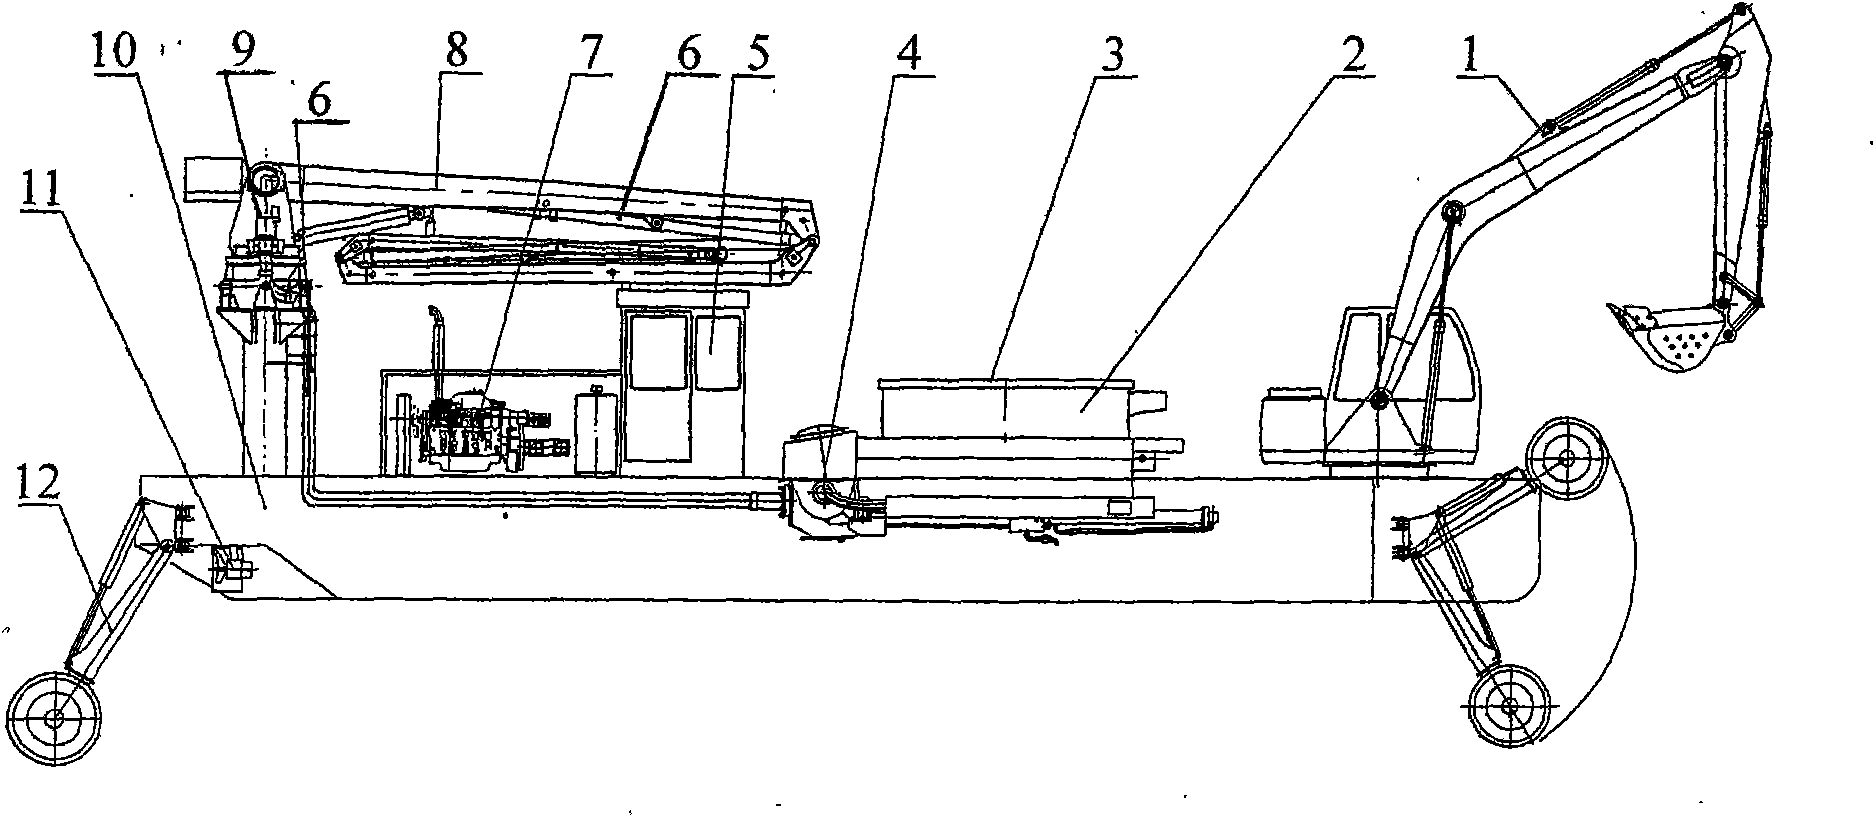
Turtle type pump dredge
InactiveCN101565957AIncrease concentrationShorten the time of precipitationWaterborne vesselsSoil-shifting machines/dredgersMarshHigh concentration
The invention relates to a turtle type pump dredge. The turtle type pump dredge is characterized in that the middle part of the dredge is provided with a displacement type slurry pump, a material distributing machine is fixed at the front part of the dredge, and the material distributing machine comprises a bracket, a supporting arm and a dredge pipe; a bench rack which can rotate for 360 degrees is arranged on the rack, the bench rack is connected with a folding supporting arm, the dredge pipe is fixed on the supporting arm and the lower end of the dredge pipe is connected with the outlet of the displacement type slurry pump. The turtle type pump dredge has the advantages: firstly, the slurry transmitted has high concentration with the solid-to-liquid ratio of 80 percent, the water precipitation time is decreased, dredge field is not needed and the thick slurry can be directly loaded into tank vessels and transmitted, thus avoiding the secondary pollution; secondly, the transmission distance is long and can usually come up to 1,000-2,000m; and thirdly, the turtle type pump dredge can run in marsh, shoals and inland rivers and lakes in cities to dispose the domestic garbage and industrial wastes in cities.
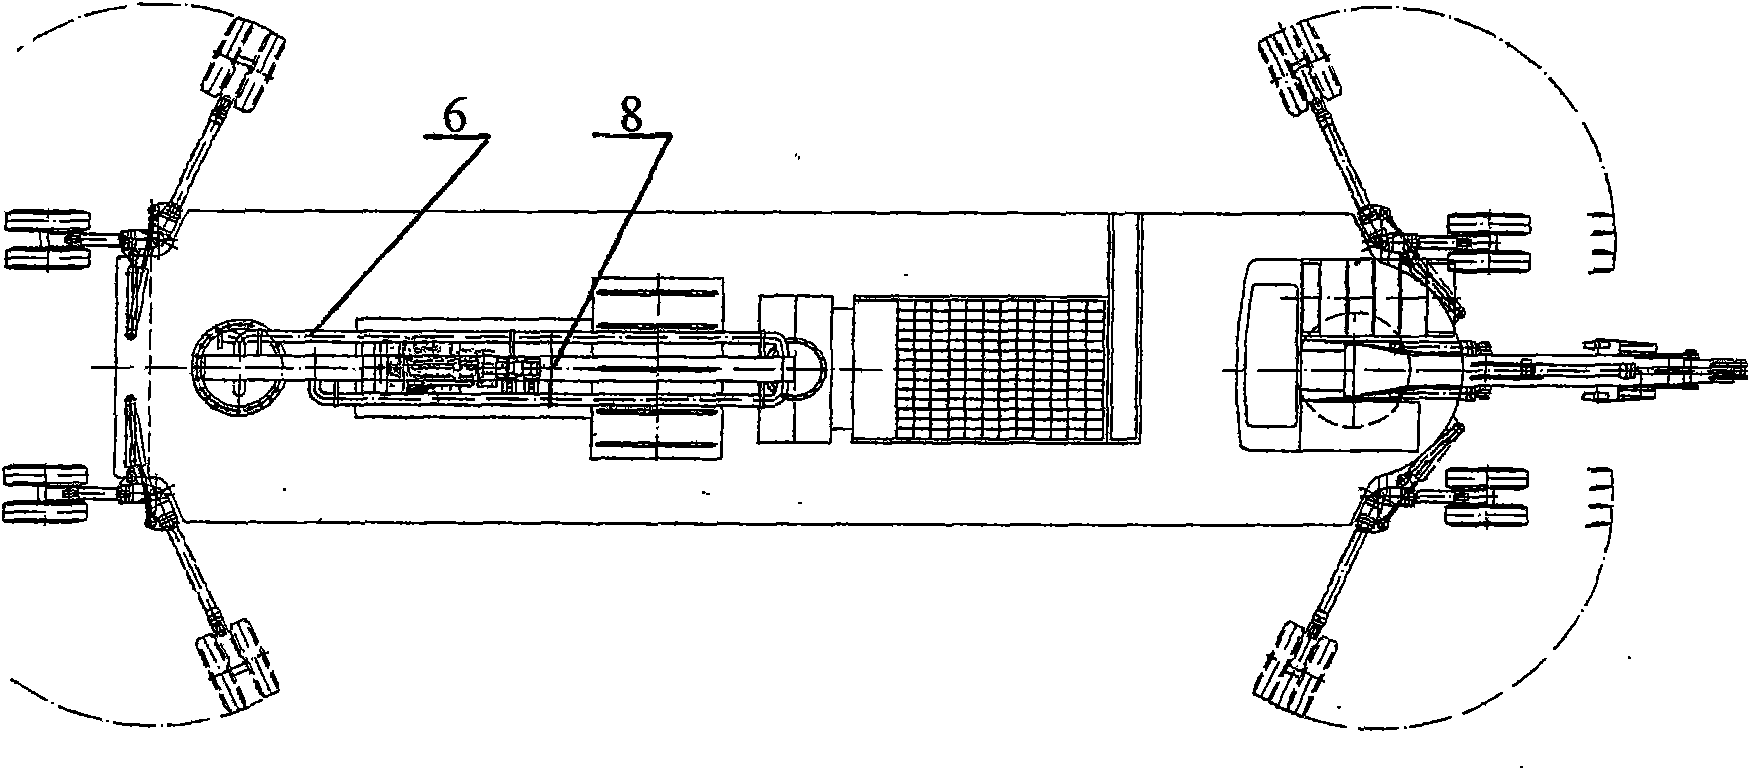
Owner:青岛国海迈斯特机械有限公司
Method and apparatus for long line and recreational bait fishing
InactiveUS20060230666A1Improve survival rateImproves hooking mechanic of hookFishing netsBaitSeabirdDecoy
Method and apparatus for long line fishing and for recreational bait fishing are disclosed. The method attaches bait to a line at a material distance from an attached and preferred circle hook. Separation of hook and bait on a line is sufficient to prevent the hook from entering a fish's mouth simultaneously with the bait. The method and apparatus are equally applicable to the branch line used in the commercial longline fishery and the line used in the recreational fishery. Line and bait attachment devices are described that allows a bait to slide on the fishing line, detach from the bait or be fixed thereon. A fish is hooked by striking bait affixed to the line at a distance from a hook. A fish's forward speed or an angler jerking the rod causes the line to be drawn through the fish's mouth and continues to pull the externally located hook until it engages with the outside of the jaw. The direction of hook-set is diametrically opposite traditional bait fishing methods. A circle hook's mechanical efficiency is improved by this method such that a recreational angler can strike a fish with the rod in traditional fashion. Separation of bait and hook by a material distance prevents a fish from swallowing a hook and promotes the survival of released fish. Additionally a line, rigged in accordance with the method, promotes the exclusion of sea turtles, sea birds and sharks from a longline catch.


Owner:MOFFITT PATRICK E
Aquatic turtle feeding block
A solid aquatic food product for turtles made from a food grade Calcium sulfate hemihydrate base and various vitamins, minerals and / or nutrients. The block is used as a food source for turtles in aquatic habitats. In addition, a method of producing the product is disclosed.
Owner:ZOO MED LAB
Remote control type machine sea turtle
The invention discloses a turtle robot. The turtle robot comprises a rectangular plastic box as a body of the turtle robot, wherein a sinking and floating mechanism controlling sinking and floating of the body of the turtle robot is formed in the rectangular plastic box; a plurality of water pumps distributed along three sides of the plastic box are fixedly connected to the outer wall of the rectangular plastic box, and the turtle robot is pushed to move forwards or leftwards and rightwards through the drainage of the water pumps; a rubbish filter is designed under the rectangular plastic box and comprises a water flow box; a propeller device is fixedly connected to the front of the water flow box and used for sucking water flow into the water flow box; a rubbish filtering net is formed behind the water flow box; a body movement driving mechanism is fixedly connected to the rubbish filter and is used for driving four limbs of the turtle robot to move; and a designed control system is used for controlling the sinking and floating mechanism, the water pumps, the body movement driving mechanism and the propeller device to work. The turtle robot is novel and reasonable in structure. Compared with other bionic turtles, the turtle robot is low in cost and integrates the functions of amusing and cleaning, thus having a high potential market value in places such as marine museums and swimming pools.
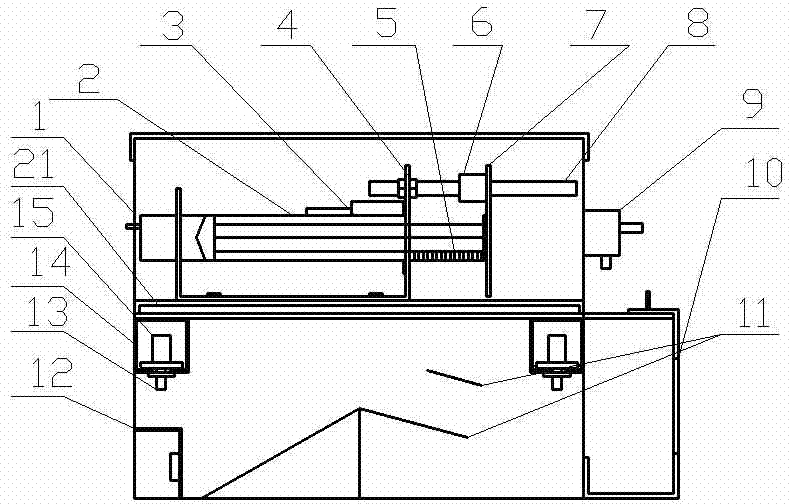
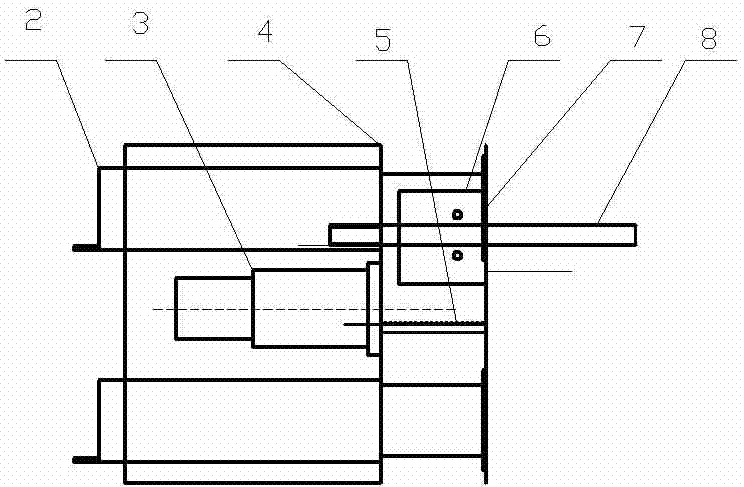
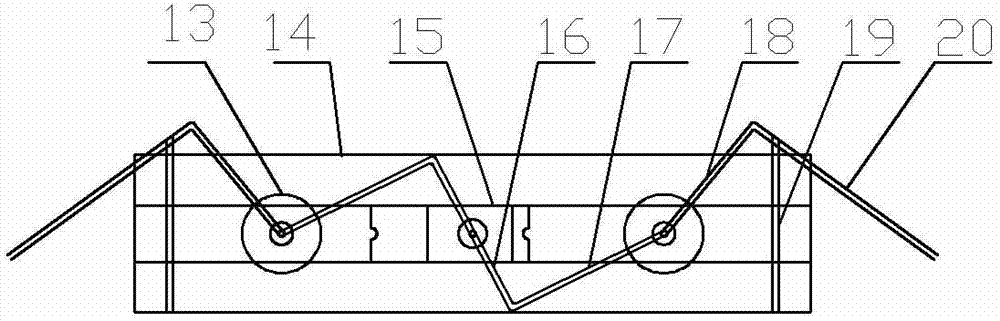
Owner:NANTONG UNIVERSITY
Hawksbill fancy glaze and firing method thereof
The invention discloses hawksbill fancy glaze which is prepared from a ground glaze body and a cover glaze body, wherein the ground glaze body is prepared from the ingredients by weight: 57 to 63 parts of feldspar, 16 to 25 parts of quartz, 8 to 15 parts of limestone, 2 to 5 parts of talc, 5 to 10 parts of ball clay, 1 to 2 parts of bone ash and 7 to 8 parts of ferric oxide; the cover glaze body is prepared from the ingredients by weight: 55 to 60 parts of feldspar, 8 to 16 parts of quartz, 16 to 21 parts of limestone, 3 to 9 parts of talc, 10 to 16 parts of ball clay, 3 to 6 parts of purple iron-containing soil and 0.1 to 0.2 part of thickener; the ferric oxide is modified. According to the hawksbill fancy glaze disclosed by the invention, the ferric oxide is modified, the modified ferricoxide can be used for preparing the ground glaze body, and a color-mixed mixture of natural black, yellow and the like can be fired out through only once firing; the hawksbill fancy glaze looks likehawksbill turtle carapace stripe porcelain, hue is vivid and moistened, the yellowish-brown stripe characteristic is obvious, and the hawksbill fancy glaze extremely has artistic value and ornamentalvalue.
Owner:JINGDEZHEN CERAMIC INSTITUTE
Diversion tunnel underwater monitoring robot and monitoring method thereof
The present invention discloses a diversion tunnel underwater monitoring robot and a monitoring method thereof. The diversion tunnel underwater monitoring robot comprises a diving robot, wherein the diving robot comprises a housing and a bionic sea turtle head, an infrared camera is arranged inside the bionic sea turtle head, both sides of the housing are respectively provided with a lifting water wing and a turning tail wing, the top surface of the housing is provided with a solar panel, one side of the solar panel is provided with a power propulsion groove, and a mechanical power mechanism, a main electric energy storage box and a standby electrical box is arranged inside the housing. According to the monitoring method, a base station transmits a signal, the signal is amplified through a movable signal conversion device, the amplified signal is transmitted to the diving robot, and the diving robot is controlled to perform underwater monitoring on the diversion tunnel. With the diversion tunnel underwater monitoring robot and the monitoring method of the present invention, the two problems of insufficient diving robot power supply and weak signal conversion receiving intensity are effectively solved, the weight of the diving robot is effectively reduced, the labor intensity is reduced, and the monitoring work radius and the control performance of the diving robot are improved.
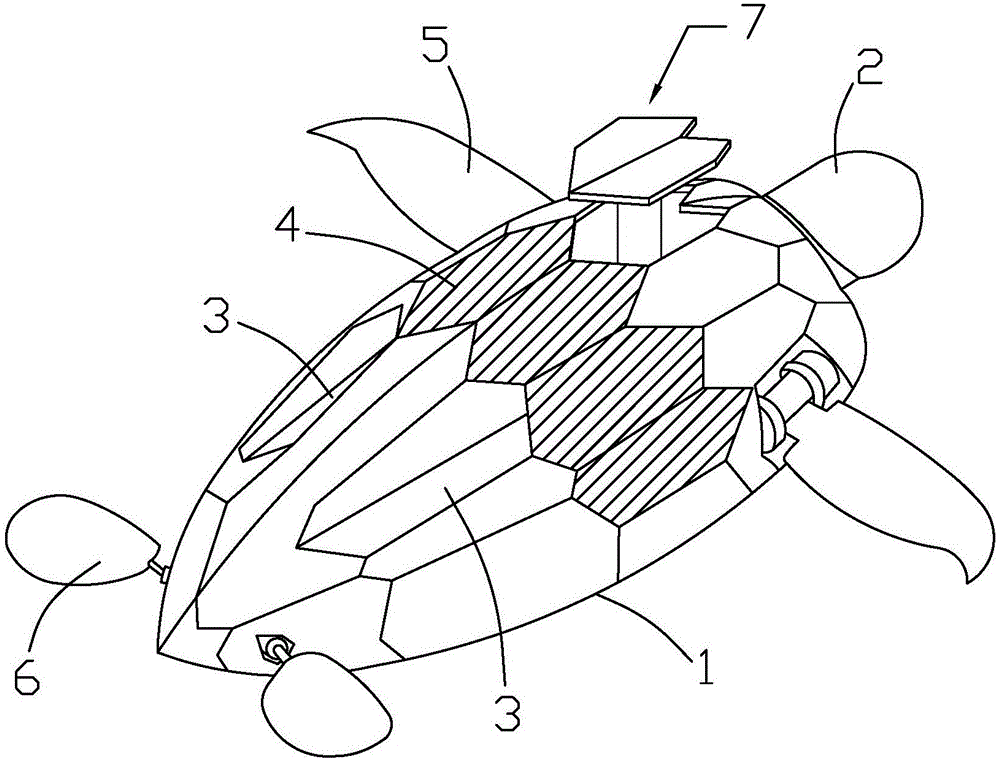
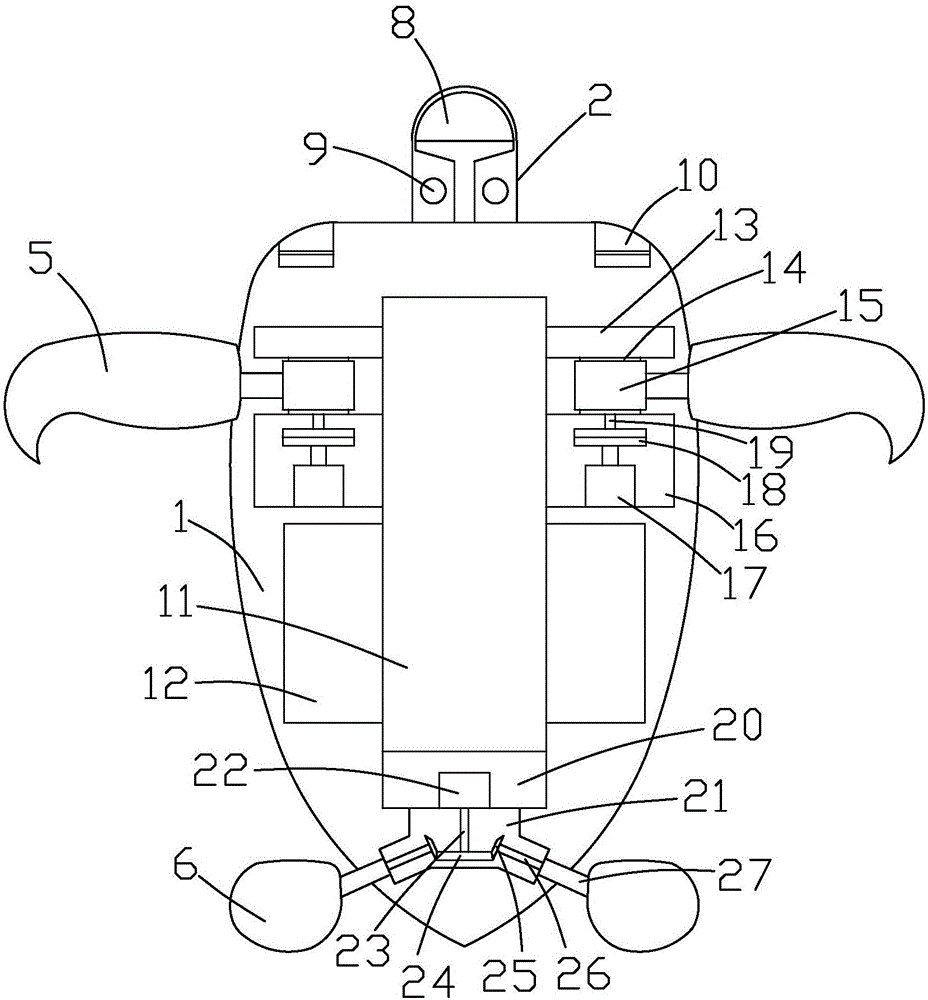
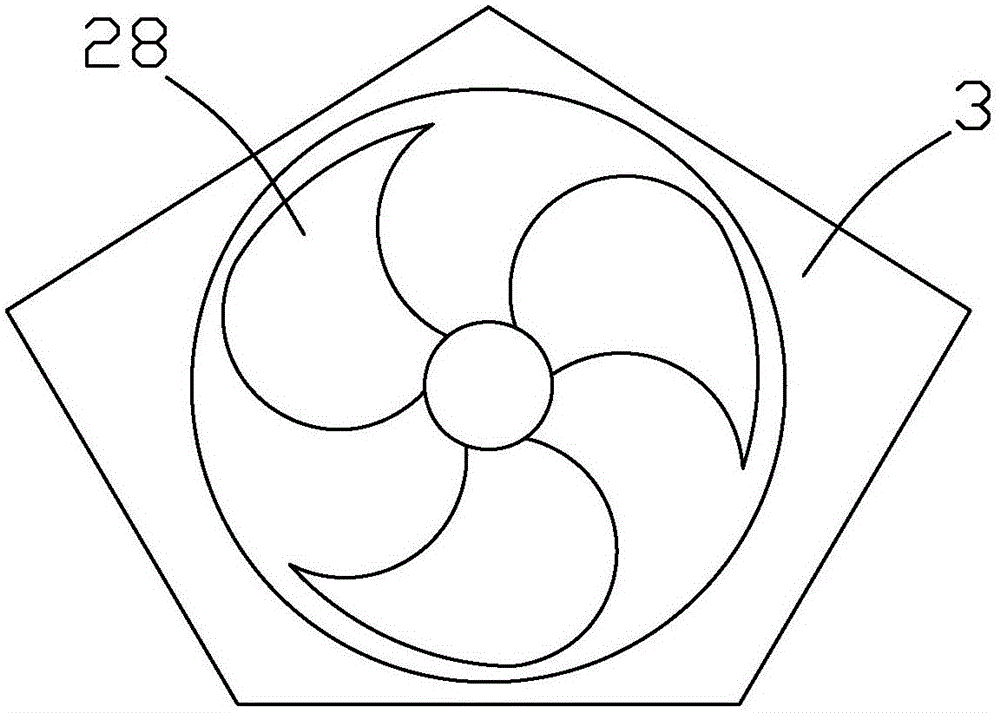
Owner:HANGZHOU HUANENG SAFETY ENG POLYTRON TECH CO LTD
Culture pond suitable for large-scale turtle and soft-shelled turtle culture
The invention discloses a culture pond suitable for large-scale turtle and soft-shelled turtle culture. The culture pond comprises a culture pond body, wherein multiple water outlets and water inlets are formed on the side wall of the culture pond body; each water inlet is connected with a water inlet pipe, and each water outlet is connected with a water outlet pipe; electromagnetic valves for controlling water feed and discharge are arranged in the water inlet pipe and the water outlet pipe; an isosceles-trapezoid hill separating a left culture area and a right culture area is arranged in the culture pond body; a feed table is arranged at the top of the hill; and a water body heating device and a water temperature control device are also arranged in the left culture area and the right culture area respectively. The culture pond body can be separated into multiple independent culture areas to adapt to the culture of each growth stage, and the quality of the cultured turtle and soft-shelled turtle is improved. The structure of the culture pond disclosed by the invention is simple and easy to realize.


Owner:广西壮族自治区乐业县科学技术情报研究所
Bionic fitness equipment
ActiveCN103785134AAvoid negative effectsSmall footprintMovement coordination devicesCardiovascular exercising devicesPhysical medicine and rehabilitationBionics
The invention relates to fitness equipment bionic in modeling and action. The appearance of the equipment is a result of turtle-crane fusion, the bionic fitness equipment comprises a crane-belly-shaped base (1), a turtle-shell-shaped cover plate (2), a turtle-body-shaped case (3), fore limbs (4), hind limbs (5), a front support (6), a rear support (7), a turtle head (8), an inner driving mechanism (9) and a circular control panel (10). The fore limbs and the hind limbs can perform a positive symmetry action, an inverse symmetry action and a cross type arc action under the driving of speed changes and direction changes of an inner motor so as to drive a body builder who lies on the turtle shell to imitate crawling of a turtle, flying of a crane, diving of the turtle, waist arching of civet, crawling of a snake, fishtailing of a tiger, leg warping of a migratory locust and other bionic actions, and massage of acupuncture points in the hands, the feet and the belly can be achieved. Compared with an existing machine, the fitness equipment has more interestingness and action diversity, integrates aesthetics, medical science and bionics, and has huge market attractiveness.
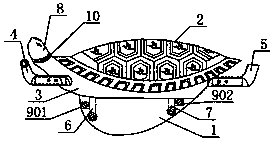
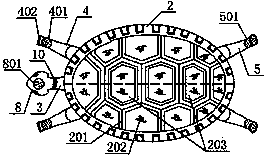
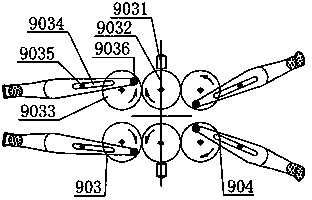
Owner:蒋日磊
Sea turtle light control system and method
Control system for sea turtle lights uses regulated lights, based upon satellite generated day signals and non-regulated lights. A user programmable timer permits the user to set time of day lighting operations. A seasonally fixed timer, fixed with a governmentally approved sea turtle season permits activation of the regulated lights. Outside of turtle season, non-regulated lights are used. The user turns ON and OFF the lights daily. An integrated lighting control system includes a central control unit having the user programmable timer and the seasonally fixed timer and the receiver with a processor and memory which generates lighting commands. A controllable light selector switch receives the lighting commands via a wired or wireless network. The method controls lights affecting sea turtles, which lights are subject to governmental regulation and seasonal operation. All light controls are further based upon the user set time of day and day of week lighting times.


Owner:FARRELL GEOFFREY
Moisturizing and brightening moisturizing essence
ActiveCN109394670AAvoid damageWill not polluteCosmetic preparationsToilet preparationsChlorella pyrenoidosa extractCrithmum maritimum extract
The invention provides a moisturizing and brightening moisturizing essence. The moisturizing and brightening moisturizing essence is characterized by being prepared from, by mass, 0.6% of seaweed extract, 0.6% of cod liver oil, 0.5% of sea turtle oil, 0. 135% of coral powder, 0.385% of rhopilema esculentum extract, 0.5% of crithmum maritimum extract, 0.6% of chlorella pyrenoidosa extract, 3% of robinia pseudoacacia extract, 2% of beeswax, 4.55% of coconut oil, 3.5% of glycerin, 5.0% of soya bean lecithin, 2.0% of sandalwood essential oil, 3.0% of prunus almond oil, 2.0% of honey, 1.0% of oliveoil and 0.6% of wheat oil. The moisturizing essence using natural materials can have roughly same technical effects as the moisturizing essence prepared by a synthetic material and avoids the damageof the synthetic material on the human body; and the production process cannot pollute the environment.


Owner:浙江神首生物科技有限公司
Traditional Chinese medicine preparation for treating hepatic cirrhosis and preparation method thereof
InactiveCN104147537ACompatibleConvenient treatmentDigestive systemUnknown materialsMedicinal herbsSide effect
The invention discloses a traditional Chinese medicine preparation for treating hepatic cirrhosis and a preparation method thereof and belongs to the field of traditional Chinese medicines. Effective components of the traditional Chinese medicine preparation comprises berberis thunbergii, thlaspi arvense, cyathula prostrata, malva crispa, zedoary, adenia heterophylla, euphorbia helioscopia, araliae roots, galinsoga parviflora, toxicodendron vernicifluum, sea turtles, diospyros rhombifolia, polygala caudate roots, camptotheca acuminata, rubus parvifolius and clematis hexapetala. The traditional Chinese medicine preparation is suitable in compatibility of medicines, has effects of regulating and tonifying liver and spleen and activating blood and resolving stasis, has significant effects on improvement and treatment of symptoms such as damage in liver and spleen, stasis in blood and qi, stasis and block in vessels and collaterals, dampness, phlegm evil and accumulation and the like, is short in treatment course, is quick to effect, is safe and convenient, is free of toxic and side effects and can be widely applied in clinical treatment of hepatic cirrhosis.
Owner:孟建军
Solar turtle carapace barnacle cleaning device
InactiveCN113000426AAvoid infectionVeterinary washing devicesCleaning using toolsEnvironmental engineeringSea turtle
The invention discloses a solar turtle carapace barnacle cleaning device. The device comprises a box body, wherein a cleaning cavity is formed in the box body, a barnacle cleaning mechanism is arranged in the cleaning cavity, and turtle catching mechanisms are arranged at the left end and the right end of the box body. The device floats within the range of a fixed point in the sea through an anchor chain, and is powered by solar energy, when sensors on the periphery of the device detect that turtles pass nearby, a power mechanism may be started to drive the device to approach the turtles, the turtles are caught into the device through a power claw and lifted away from the water surface for barnacle cleaning, and the cleaned turtles can stay in the dark environment in the device for a week, during the period, the turtles are flushed with disinfected seawater regularly to prevent the condition that the turtles are directly released into the sea and cause wound infection, and the turtles are released back into the sea when possible wounds start to heal in one week.


Owner:南京慕诗图家具有限公司
Sea turtle egg incubator special for sea turtle breeding
The invention discloses a sea turtle egg incubator special for sea turtle breeding. The sea turtle egg incubator comprises an incubation box, wherein incubation cavities are arranged in the incubationbox in a bilateral symmetry manner, a transmission cavity is arranged between the two incubation cavities, a bent cavity is arranged on one side away from the transmission cavity, of each incubationcavity, and the two bent cavities are in bilateral symmetry; a sliding cavity is arranged on the bottom wall of each bent cavity, and a spring cavity is arranged on the bottom wall of each sliding cavity; a humidifying motor is switched on, so that a motor shaft is driven to rotate, then second belt wheels and an auxiliary shaft are driven to rotate, a humidifying board is driven to move upwards,and water in a water storing cavity is sprayed into the incubation cavities through atomizing spray heads. Compared with traditional artificial incubation or sea turtle autonomous incubation, the seaturtle egg incubator disclosed by the invention has the advantages that the step in the incubation process is greatly simplified, and the labor cost for incubating sea turtles can be reduced.


Owner:龙游纯平宠物用品有限公司
Antibacterial peptide hrNCM as well as preparation method and application thereof
ActiveCN113999297ABroad-spectrum high-efficiency antibacterial activityGood anti-inflammatory activityAntibacterial agentsCosmetic preparationsAntibacterial activitySea turtle
The invention discloses an antibacterial peptide hrNCM as well as a preparation method and an application thereof. According to an amino acid sequence of the green sea turtle antibacterial peptide, a modified body hrNCM is designed by utilizing a molecular modification method, and the modified body has broad-spectrum and efficient antibacterial activity and very strong anti-inflammatory activity and also has the beneficial characteristics of small molecular weight, simple structure, low hemolytic activity, simple preparation method, high stability and the like.
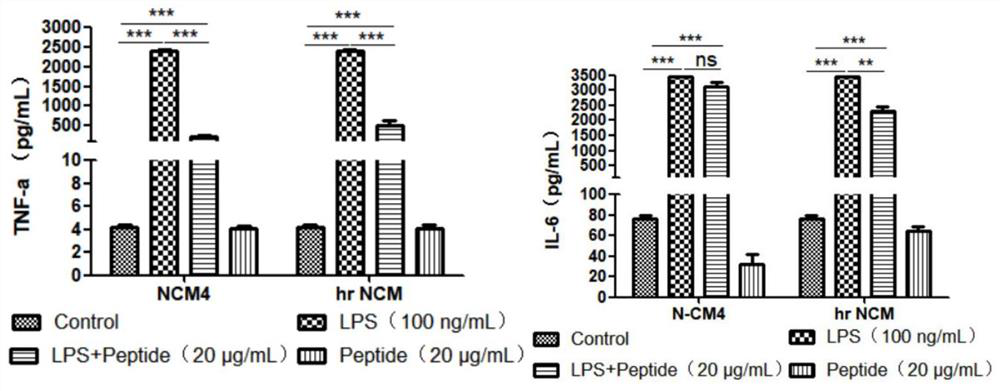
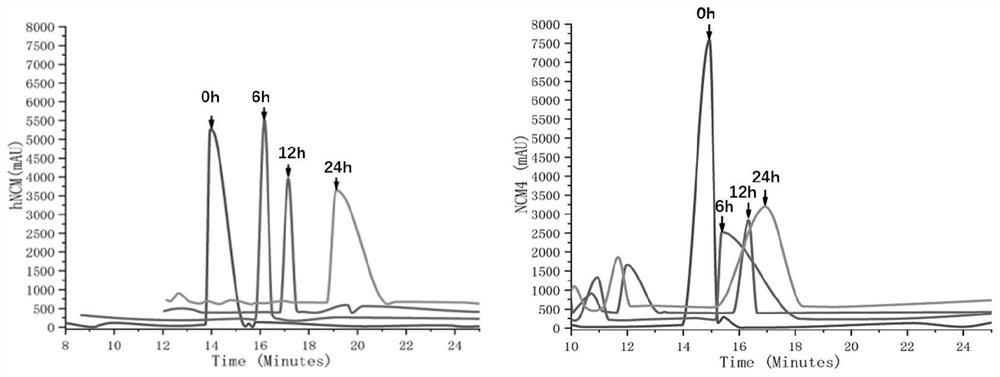
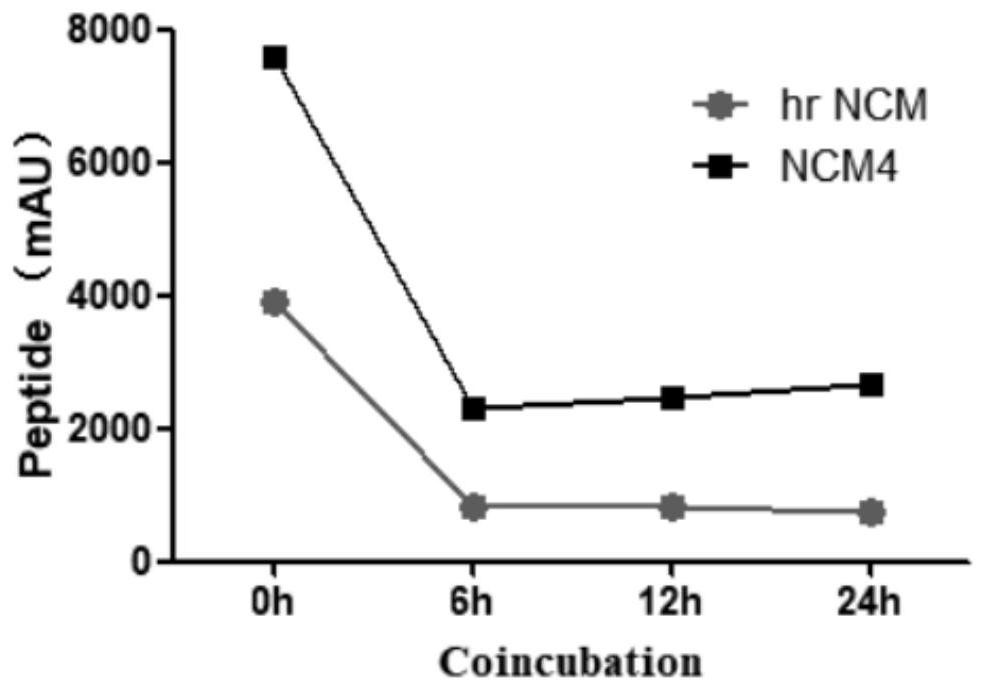
Owner:苏州市第九人民医院
Culure method for green turtles at three months old or younger
InactiveCN106879549AReasonably control the densityNutritional balanceAnimal feeding stuffSea turtleShrimp culture
The invention discloses a culture method for green turtles at three months old or younger. The culture method is characterized by comprising the following steps of culture pond improving, wherein a culture pond of the green turtles is obtained by improving a sea shrimp culture pond, the periphery of the sea shrimp culture pond is improved into slopes, a fence is built around the pond, and the improved culture pond is exposed under the sun for 3 days or above; seawater pretreating, wherein standing and precipitating are conducted on seawater for 10-12 h; pond entering of the seawater, wherein the pretreated seawater is guided into the culture pond, and the water surface in the pond is 0.3-0.5 m lower than the highest portion of the culture pond; young turtle stocking, wherein young green turtles are put into the culture pond, the young turtle density is controlled to be 100-120 / m<3>, and the young turtles are cultured for 30-35 days; density lowering, wherein after the young turtles are cultured for 30-35 days, part of the green turtles are transferred to other culture ponds, and the green turtle density is controlled to be 30-40 / m<3>; culture managing, wherein managing in the culture process of the green turtles comprises feeding, water changing, water temperature managing and diseased turtle clearing. According to the method, by reasonably controlling the density of the turtles, the feeding frequency and the bait proportion, the survival rate of the green turtles is 95% or above.
Owner:广西精工海洋科技有限公司
Antibacterial peptide CCM7WC as well as preparation method and application thereof
PendingCN113735956ABroad-spectrum high-efficiency antibacterial activityLow cytotoxicityAntibacterial agentsCosmetic preparationsCytotoxicityAntibacterial activity
The invention discloses an antibacterial peptide CCM7WC as well as a preparation method and application thereof. According to the antibacterial peptide CCM7WC as well as the preparation method and application thereof, a modified body CCM7WC is designed by utilizing a molecular modification method according to an amino acid sequence of an antibacterial peptide of a green sea turtle, and the modified body has broad-spectrum efficient antibacterial activity, low cytotoxicity and high stability and furthermore has the beneficial characteristics of small molecular weight, simple structure, simple preparation method and the like.


Owner:苏州市第九人民医院
Fishing lure
A fishing lure adapted to mimic sea turtle hatchlings in size, shape and movement is provided. The replica lure may provide a plurality of planar lure members that sandwich a proximal portion of a hook so that the distal portion is disposed adjacent to and underneath the mimicked sea turtle profile. The proximal end of the hook may provide a built up portion that is sandwiched, thereby providing voids between some of the plurality of lure members further mimicking the profile of a baby sea turtle, while also enabling a seesaw effect when the replica lure and / or hook is bitten by a fish.


Owner:COOK DANA CHRISTOPHER
Propelling device imitating front fins of sea lion
ActiveCN111976938AEfficient propulsion performanceImprove efficiencyPropulsive elements of non-rotary typeUnderwater equipmentMarine engineeringSea lion
The invention discloses a propelling device imitating front fins of a sea lion. The propelling device comprises a base unit, a driving unit, wobble plate mechanisms, space crank rocker mechanisms andflexible units imitating the front fins of the sea lion. The driving unit drives the wobble plate mechanisms and the space crank rocker mechanisms which are connected in series so that the flexible units imitating the front fins of the sea lion can imitate the movement characteristics of the front fins of the sea lion and the propelling principle based on both lift force and resistance. And meanwhile, the device has an oval movement trail similar to that of the front fins of the sea lion and periodic change of the front fin attack angles, and has high propelling efficiency and maneuverability.The flexible units imitating the front fins of the sea lion have the bone density, appearance and flexibility characteristics similar to those of the front fins of the sea lion, have the good hydrodynamic characteristic and improve the propelling efficiency. According to the propelling device, the movement track, the turning direction, the power characteristics and the thrust of the mechanism canbe adjusted in multiple aspects so that the device can adapt to different underwater movement conditions. In addition, through adjustment, the device can generate a movement trail similar to an 8 shape of the forelimbs of a sea turtle.


Owner:TIANJIN UNIV
Reducing by-catch of seabirds
An apparatus for reducing by-catch of seabirds or turtles during fishing include a fish hook (220) and a barrier or shield (227) mounted in a position relative to the fish hook (220) such that the barrier (227) reduces or prevents hooking of a seabird or turtle by the fish hook or ingestion of the hook by a seabird or turtle. The apparatus includes a degradable component (226) that degrades when placed in water such that when the degradable component degrades the barrier moves away from the position relative to the fish hook or no longer exists to allow the fish hook to be taken by a fish. The degradable component (226) may be a retaining means or a mounting means. The degradable component may form part of, or all of, the barrier.


Owner:HUNA HLDG PTY LTD ON BEHALF OF HJ FAMILY TRUST
Sea-turtle-imitating robot for submarine pipeline leakage monitoring and multi-mode control method of sea-turtle-imitating robot
PendingCN119429038Areduce pollutionReduce maintenance costsPropulsive elements of non-rotary typeVehicle position/course/altitude controlMode controlGravity center
The invention discloses a sea-turtle-imitating robot for submarine pipeline leakage monitoring and a multi-mode control method thereof.The sea-turtle-imitating robot comprises a trunk, a head, a top cover, two pectoral fin plates, a tail fin plate, pectoral fin driving devices, a gravity center adjusting mechanism and a detection control unit, and the two pectoral fin plates are symmetrically arranged on the left side and the right side of the front portion of the trunk; two pectoral fin driving devices are arranged on the inner side of the trunk in a bilateral symmetry mode, and each pectoral fin driving device drives the pectoral fin plate on the same side to move front and back and adjusts the angle posture of the pectoral fin plate. The gravity center adjusting mechanism comprises a balancing weight, a linear guide mechanism and a servo motor, and the servo motor drives the balancing weight to move front and back. Two second steering engines are symmetrically arranged on the two sides of the rear end of the trunk, the two tail fin plates are located on the left side and the right side of the rear portion of the trunk, and the execution ends of the second steering engines drive the tail fin plates on the same sides to swing up and down. According to the invention, polling along the sea bottom pipeline is realized through attitude control, image information is adopted and whether leakage occurs is judged, the maintenance cost is low, a leakage point can be found in time, and economic loss is reduced.

Owner:HARBIN ENG UNIV QINGDAO SHIP TECH CO LTD +1
Traditional Chinese medicament for treating premature climacteric
InactiveCN103566347ANo significant differenceComparableSexual disorderFish material medical ingredientsBiotechnologyMedicinal herbs
The invention relates to a traditional Chinese medicament for treating premature climacteric. The traditional Chinese medicament is prepared from the following medicinal materials in parts by weight: 12 parts of Chinese angelica, 12 parts of Chinese date, 7 parts of dried ginger, 7 parts of chelonia glue, 7 parts of sea cucumber, 6 parts of sea urchin, 6 parts of turbot skin, 6 parts of globefish, 6 parts of dried scallop, 6 parts of seahorse, 6 parts of razor clam, and 6 parts of clam. Clinical experiments prove that the traditional Chinese medicament can safely and effectively treat premature climacteric.
Owner:李树欣 +2
Traditional Chinese medicine pills for treating night sweat and preparation method thereof
InactiveCN105535623AGood antiperspirant effectPrevent relapseDrug compositionsPill deliveryPolygonum fagopyrumTreatment effect
The invention discloses traditional Chinese medicine pills for treating night sweat and a preparation method thereof. The traditional Chinese medicine pills are prepared from, by weight, 15-17 parts of sea turtle glue, 4-8 parts of Polygala subopposita S.K.Chen, 5-7 parts of lotus petiole, 8-10 parts of Potentilla limprichtii J. Krause, 12-14 parts of black beans, 2-4 parts of blood vines, 3-5 parts of Zanthoxylum bungeanum Maxim, 6-8 parts of pinanga tashiroi, 10-12 parts of donkey-hide gelatin, 5-7 parts of fallopia nervosa, 15-17 parts of bamboo juice, 2-4 parts of beggarweed, 8-10 parts of Syzygium grijsii (Hance) Merr. Et Perry, 10-12 parts of dwarf mallow roots, 7-9 parts of Lespedeza cuneata G. Don, 14-16 parts of fimbristylis rigidula, 4-6 parts of water spinach roots, 8-10 parts of pygmy fruits of peaches, 5-7 parts of sipunculus nudus, 2-4 parts of bidens frondosa, 20-22 parts of buckwheat and 30-32 parts of honey. The traditional Chinese medicine pills for treating night sweat is good in treatment effect and low in relapse rate.


Owner:夏放军
Double-propulsion water area detection bionic sea turtle with drug delivery function
The invention relates to the technical field of underwater operation robots, and particularly discloses a double-propulsion water area detection bionic sea turtle with drug delivery, which comprises a central deck, a bionic forelimb is arranged on the front side of the top of the central deck, and a bionic hind limb linked with the bionic forelimb is arranged on the rear side of the top of the central deck. Spiral propellers are arranged on the two sides of the central deck, and a walking crawler belt is arranged at the bottom of the central deck; a stock bin is arranged on the rear side of the top of the center deck. According to the double-propulsion water area detection bionic sea turtle with the drug delivery function, the walking crawler belt can be used for advancing on the land, and people do not need to put the bionic sea turtle into a swimming water area; the spiral propeller can be used as power to advance in a fish-free water area, so that the advancing efficiency is ensured; the bionic forelegs and the bionic hind limbs are used as propelling power in the culture area, and fish schools cannot be disturbed. Meanwhile, the bionic forelegs and the bionic hind limbs are linked through the linkage rods, and driving equipment is saved.

Owner:SHENYANG LINDONG BIONIC TECH CO LTD
Sea-turtle-imitating amphibious robot terrain classification and self-adaptive gait switching method based on visual tactile perception
The invention discloses a terrain classification and self-adaptive gait switching method for a sea-turtle-imitating amphibious robot based on visual tactile perception. The method comprises the following steps: establishing a robot model carrying a pressure sensor and a waterproof camera; the method comprises the following steps: acquiring tactile time sequence data and visual images in various terrains such as broken stones and sand beaches, and constructing a training data set; establishing a multi-modal convolutional neural network, and fusing features through dual-channel feature extraction and an adaptive attention mechanism; motion energy consumption and speed under each terrain are collected, and the optimal gait is determined; and constructing a gait switching finite-state machine in combination with terrain physical attribute classification and the optimal gait. According to the method, a sensing-decision-driving closed loop is formed, the terrain is sensed through visual touch, the gait is decided through a finite-state machine, the gait driving motion is executed, and through experimental verification, the self-adaptive gait can improve the moving efficiency and speed, and the amphibious environment adaptability of the robot is enhanced.

Owner:TSINGHUA SHENZHEN INTERNATIONAL GRADUATE SCHOOL
Turtle Sunning Terrace
1. The name of this design product: Turtle sunbathing platform. 2. Purpose of this product with design: This product with design is used for turtle breeding and is placed on the fish tank to provide a platform for the turtle to receive light. 3. The design key point of this appearance design product lies in the shape. 4. The picture or photo that best illustrates the design points: Stereoscopic diagram 1.

Owner:LEYOULU (SHENZHEN) TECHNOLOGY CO LTD