

Patents
Literature
47results about How to "Improve usage sensitivity" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Magnetic flourescent nano material for magnetic-photo sensor and preparation method thereof
InactiveCN101723311AQuick responseImprove the accuracy of useIndividual molecule manipulationInorganic material magnetismQuantum yieldFiber
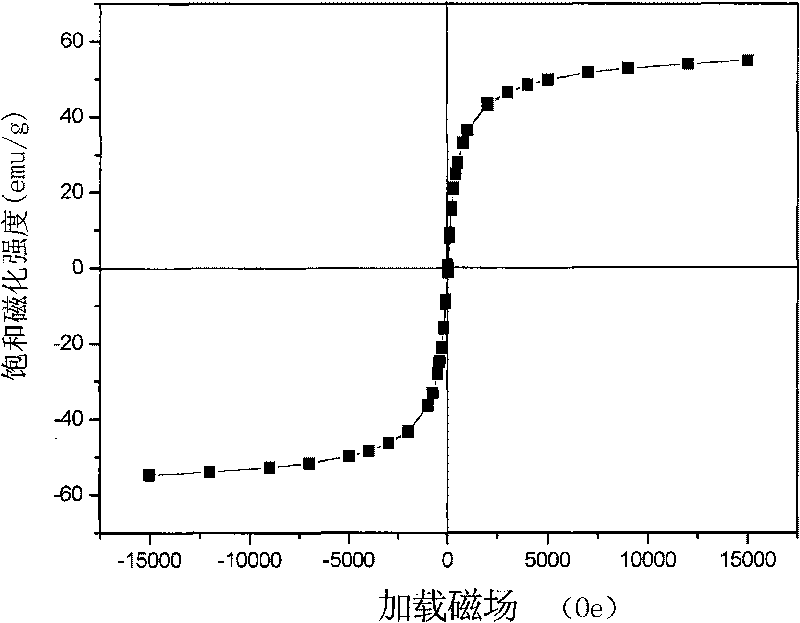
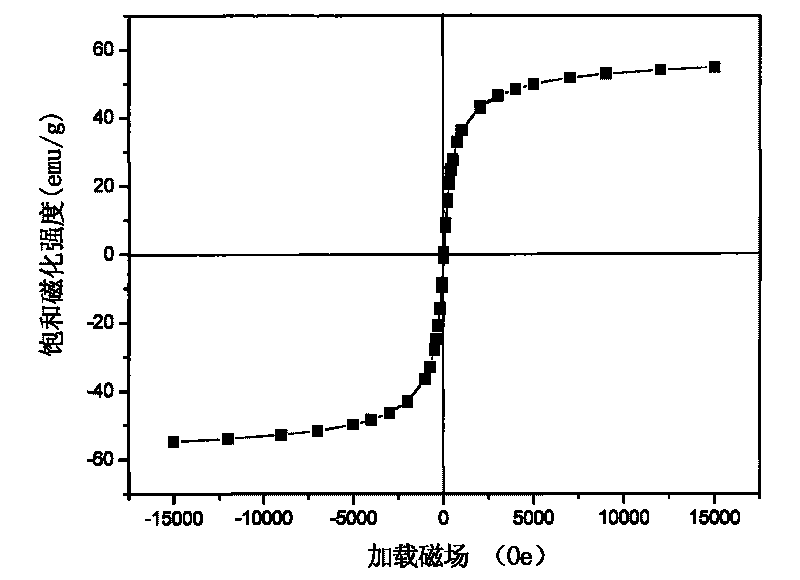
The invention provides a magnetic flourescent nano material for a magnetic-photo sensor and a preparation method thereof. The material is a magnetic flourescent nano material based on nano tubes or nano-fiber micro templates and comprises a tubular or fibroid nano material template with a carboxylic acid functional group, a magnetic material, a biparental molecular material and a quantum dot material. The functional group of the template is chelated with Fe<2+>, Fe<3+>, or Co<2+>; the magnetic material such as Fe2O3, Fe3O4, or FeCo generated after reaction under the action of alkali grows on the surface of the template; the biparental molecule is gelatin, amino acid, polypeptide, or dendroid with a carboxylic end group, one end of which contains carboxyl and the other end contains amino or sulfydryl; the carboxyl of polyamide-amine which is a dendroid molecule is chelated with Fe2O3, Fe3O4, or FeCo nano grains on the template; the amino or the sulfydryl is combined with the quantum dot to obtain the megnetic flourescent nano material through assembling. The nano material has strong magnetic property, high quantum yield and good electrical property. After applied to the preparation of magnetic-photo sensors, the nano material can improve the accuracy and the sensitivity of the magnetic-photo sensors.
Owner:WUHAN UNIV OF TECH
Acridine marker conjugate and preparation method thereof and chemiluminescent kit
InactiveCN106053443AHigh activityIncrease steric hindranceAntibody mimetics/scaffoldsSerum albuminAcridineChemical Linkage
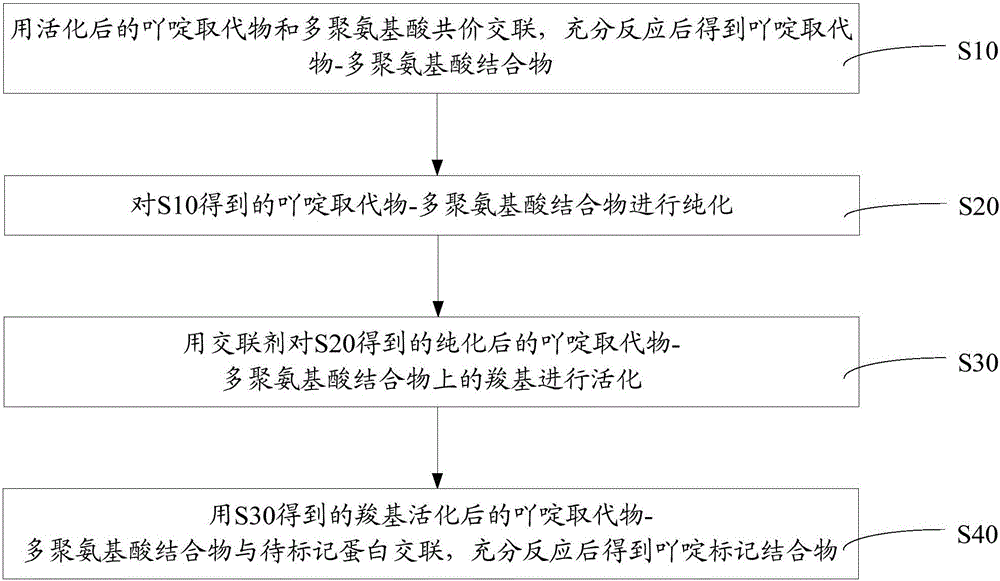
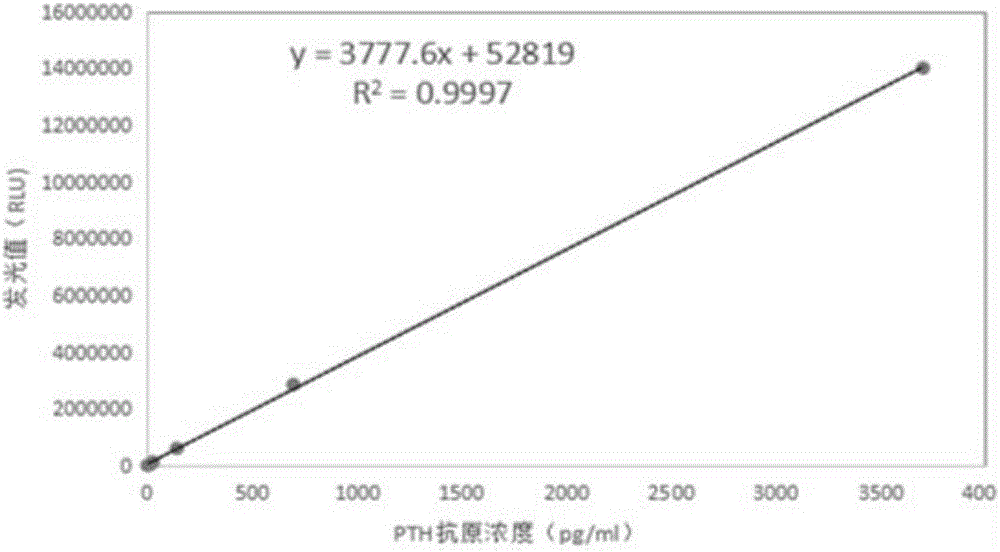
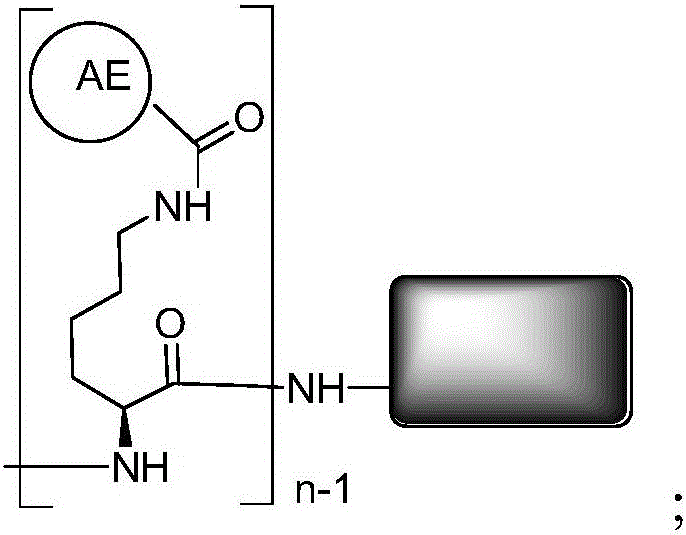
The invention discloses an acridine marker conjugate and a preparation method thereof and a chemiluminescent kit. The acridine marker conjugate comprises an acridine substitute, polyamino acid and to-be-marked protein; the polyamino acid contains carboxyl and amino; the to-be-marked protein is amino protein, modified protein, polypeptide or modified polypeptide. The polyamino acid of the acridine marker conjugate reacts with the acridine substitute through the amino of the polyamino acid to form chemical bond connection, the amino of the to-be-marked protein reacts with the carboxyl of the polyamino acid to form a -NH-CO- structure, and accordingly the polyamino acid and the to-be-marked protein are connected together, active sites of the to-be-marked protein are protected from being interfered by the acridine substitute due to relative determinacy of binding sites, and the acridine marker conjugate is relatively high in activity.
Owner:SHENZHEN YHLO BIOTECH
Magnet type plunger pump
InactiveCN104033378AExtended service lifeImprove usage sensitivityPositive displacement pump componentsLiquid fuel engine componentsEngineeringCylinder block
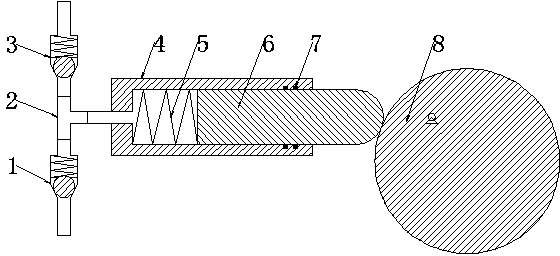
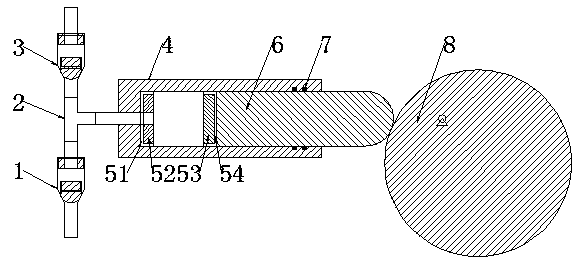
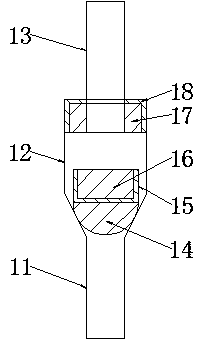
A magnet type plunger pump comprises a liquid inlet check valve, a tee joint device, a liquid outlet check valve, a cylinder body, a plunger, a seal ring and an eccentric wheel. An annular hollow permanent magnet of the cylinder body is arranged at a liquid access port of the cylinder body, and a hollow magnetic shield of the cylinder body is arranged between the cylinder body and the annular hollow permanent magnet of the cylinder body; an annular solid permanent magnet of the plunger is arranged at the inner end of the plunger, and a concave magnetic shield of the plunger is arranged between the plunger and the annular solid permanent magnet of the plunger; the annular solid permanent magnet of the plunger and the annular hollow permanent magnet of the cylinder body are arranged in opposite and repel mutually; the liquid inlet check valve and the liquid outlet check valve are both magnet type check valves. The magnet type plunger pump has the advantages that since reset springs in existing plunger pumps are replaced by the annular solid permanent magnet of the plunger and the annular hollow permanent magnet of the cylinder body which are arranged in opposite, service life of the plunger pump is remarkably prolonged, and flexibility of the plunger pump is evidently improved.
Owner:吉林省东元精密机械有限公司
Heat-conducting flame-retardant epoxy resin composite material and preparation method thereof
ActiveCN110079050AImprove flame retardant performanceGood thermal conductivity and flame retardant performanceHeat-exchange elementsEpoxy resin compositeThermal conductivity
The invention belongs to the field of composite materials, and discloses a heat-conducting flame-retardant epoxy resin composite material and a preparation method thereof. The composite material comprises an epoxy resin matrix and molybdenum disulfide coated reduced graphene oxide-silver nanowire aerogel, wherein the molybdenum disulfide coated reduced graphene oxide-silver nanowire aerogel is dispersed in the epoxy resin matrix; and the volume ratio of the epoxy resin matrix material to the molybdenum disulfide coated reduced graphene oxide-silver nanowire aerogel is 100: 1-100: 5. Accordingto the heat-conducting flame-retardant epoxy resin composite material, the molybdenum disulfide coated reduced graphene oxide-silver nanowire aerogel is added into the epoxy resin to serve as a filler, the adding ratio of the filler is controlled, and meanwhile, the overall process flow design and the like of the preparation method of the composite material are improved, so that the technical problems that the thermal conductivity and the flame retardance of an existing electronic packaging material are poor, and the processing performance and the mechanical performance of the epoxy resin matrix are influenced when too much filler is added can be solved.
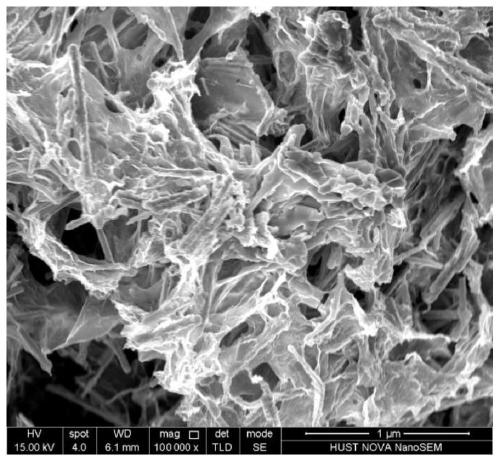
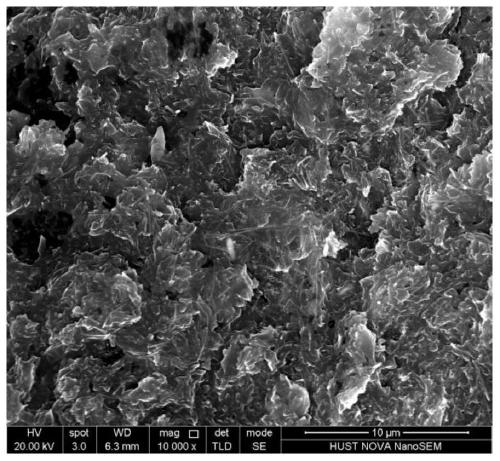
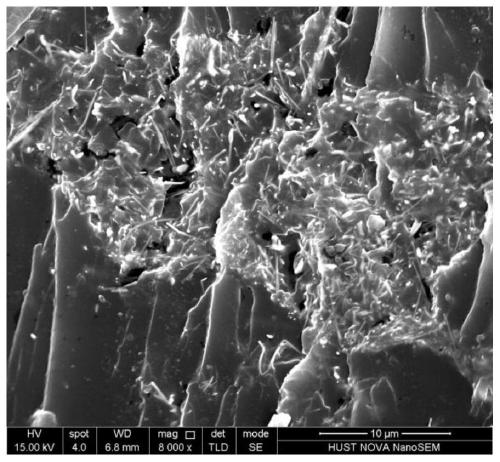
Owner:HUAZHONG UNIV OF SCI & TECH
Acridine marker conjugate and preparation method thereof and chemiluminescence immunoassay kit
ActiveCN106146672AHigh activityStrong specificityAntibody mimetics/scaffoldsChemiluminescene/bioluminescenceCross-linkAcridine
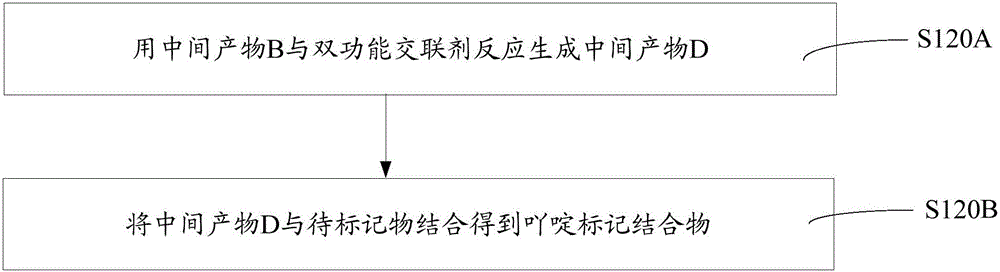
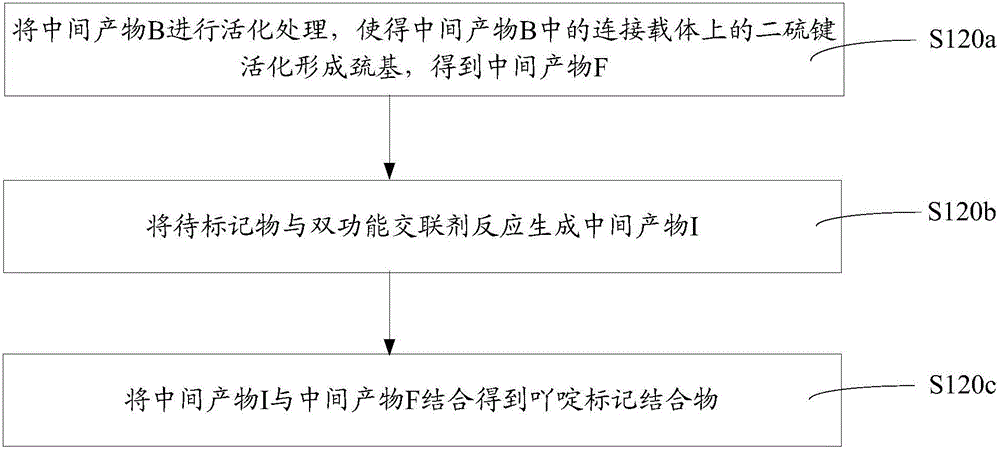
The invention discloses an acridine marker conjugate and a preparation method thereof and a chemiluminescence immunoassay kit. The acridine marker conjugate comprises an acridine substitute, a connecting carrier, a difunctional cross-linking agent and an object to be marked which are connected in sequence. The acridine substitute and amidogen on the connecting carrier react to form a -CO-NH- structure so as to connect the acridine substitute with the connecting carrier. By means of the connecting carrier and the difunctional cross-linking agent containing a maleimide group and a hydrazide group, the acridine substitute and the object to be marked are not subjected to chemical bond connection directly, interference is formed by the acridine substitute on an active site on the object to be marked is avoided, the activity of the acridine marker conjugate is made higher, and the sensitivity of immunoassay is improved.
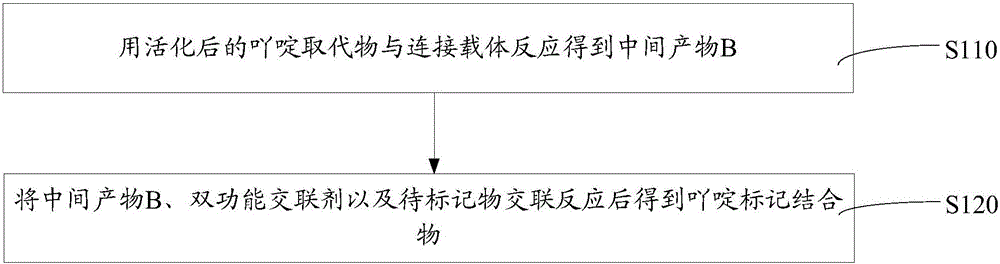
Owner:SHENZHEN YHLO BIOTECH
Acridine marker conjugate, preparation method of acridine marker conjugate and chemical luminescent kit
InactiveCN106124777AHigh activityIncrease steric hindranceAntibody mimetics/scaffoldsSerum albuminAcridineCarboxyl radical
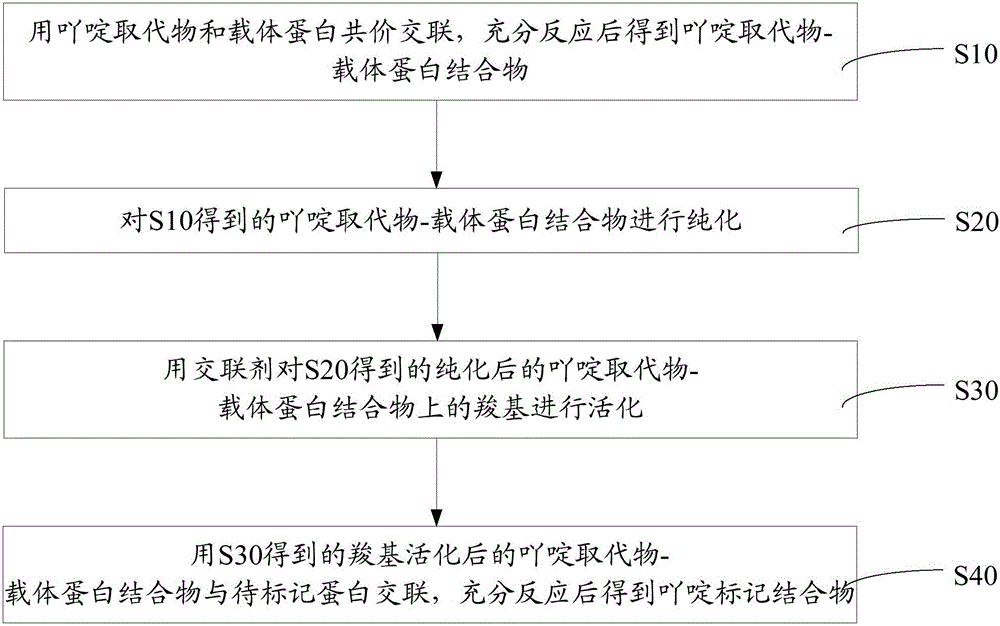
The invention discloses an acridine-labeled conjugate, a preparation method thereof, and a chemiluminescence kit. The acridine-labeled conjugate includes acridine substituents connected in sequence, a carrier protein and a protein to be labeled; the carrier protein is a carboxyl- and amino-containing Protein, modified protein, polypeptide or modified polypeptide; the protein to be labeled is amino-containing protein, modified protein, polypeptide or modified polypeptide. The carrier protein of this acridine-labeled conjugate forms a chemical bond connection through the reaction of the amino group on the carrier protein with the acridine substituent, and the amino group on the protein to be labeled reacts with the carboxyl group on the carrier protein to form a ‑NH‑CO‑structure so that the carrier protein Linked with the protein to be labeled, the binding site is relatively definite, avoiding the interference of the acridine substitute on the active site on the protein to be labeled, and the activity of this acridine-labeled conjugate is relatively high.
Owner:SHENZHEN YHLO BIOTECH
Integrated pressure-sensitive fingerprint packaging structure and fingerprint module
PendingCN107293524AImprove usage sensitivityImprove use reliabilitySemiconductor/solid-state device detailsSolid-state devicesPressure senseDesign space
The invention discloses an integrated pressure-sensitive fingerprint packaging structure and an integrated pressure-sensitive fingerprint module. The integrated pressure-sensitive fingerprint packaging structure integrally packages a pressure sensing module and a fingerprint biological identification module in the same structure, thus a new fingerprint packaging method is proposed, namely, the traditional pressure sensing module (a thin film pressure sensitive piece) and the fingerprint identification module (a fingerprint chip) are integrated in the same packaging structure, thus the packaging structure as a stress sensing characteristic of a pressure sensing thin film and a fingerprint biological identification characteristic of a silicon wafer, and the use flexibility and reliability of pressure and fingerprints can be effectively improved, therefore, the design space is reduced, the performances are improved, a new interactive experience is brought for various types of electronic interactive equipment, and the equipment interacting on the mobile internet is more effective and rapid.


Owner:昆山丘钛生物识别科技有限公司
Microelectromechanical sensor
ActiveCN110290450AImprove damageBalance the pressure difference inside and outsideSemiconductor electrostatic transducersMaterial analysis by electric/magnetic meansMicroelectromechanical systemsEngineering
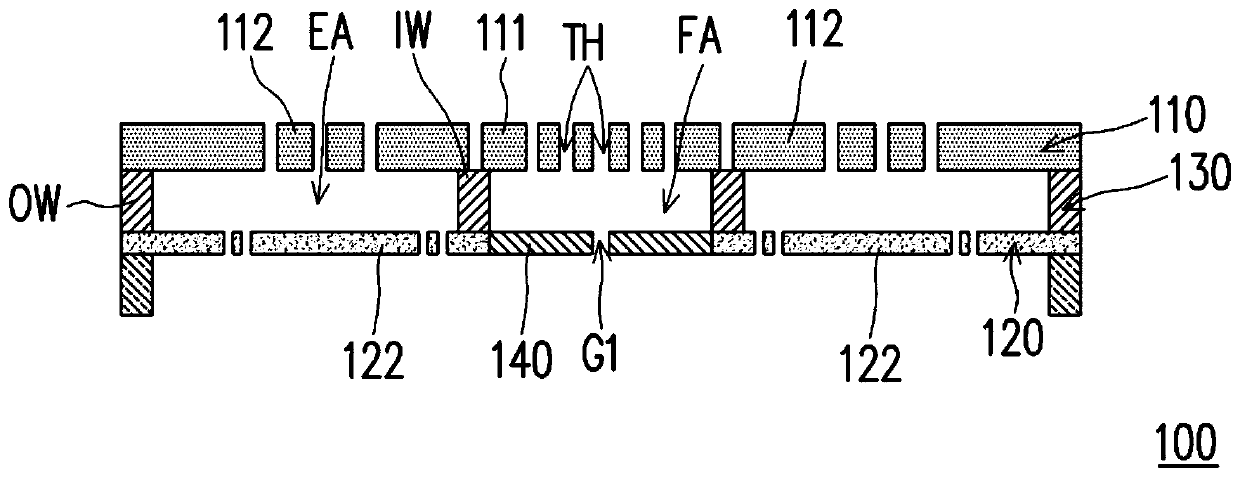
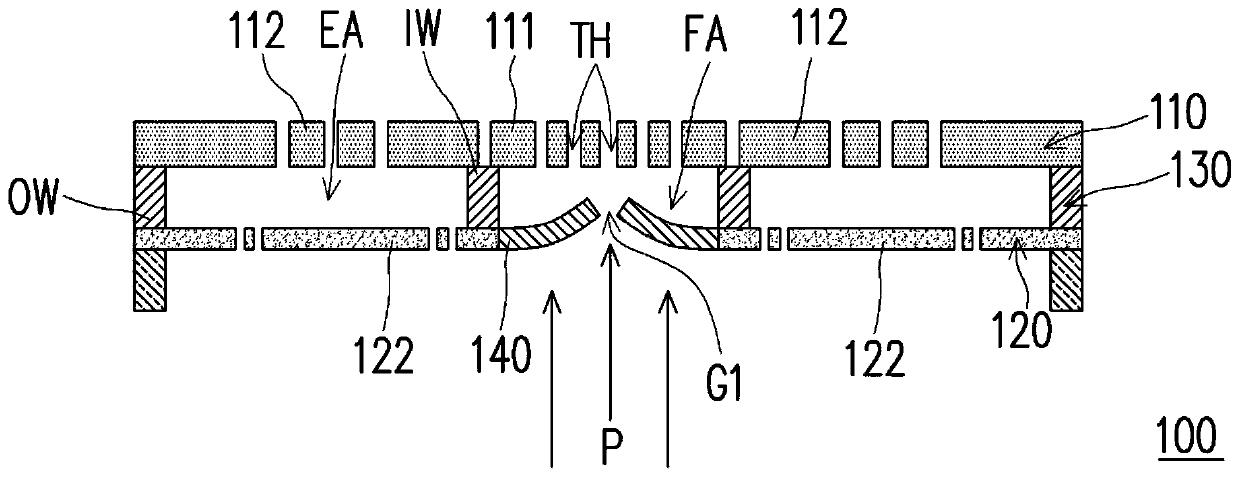
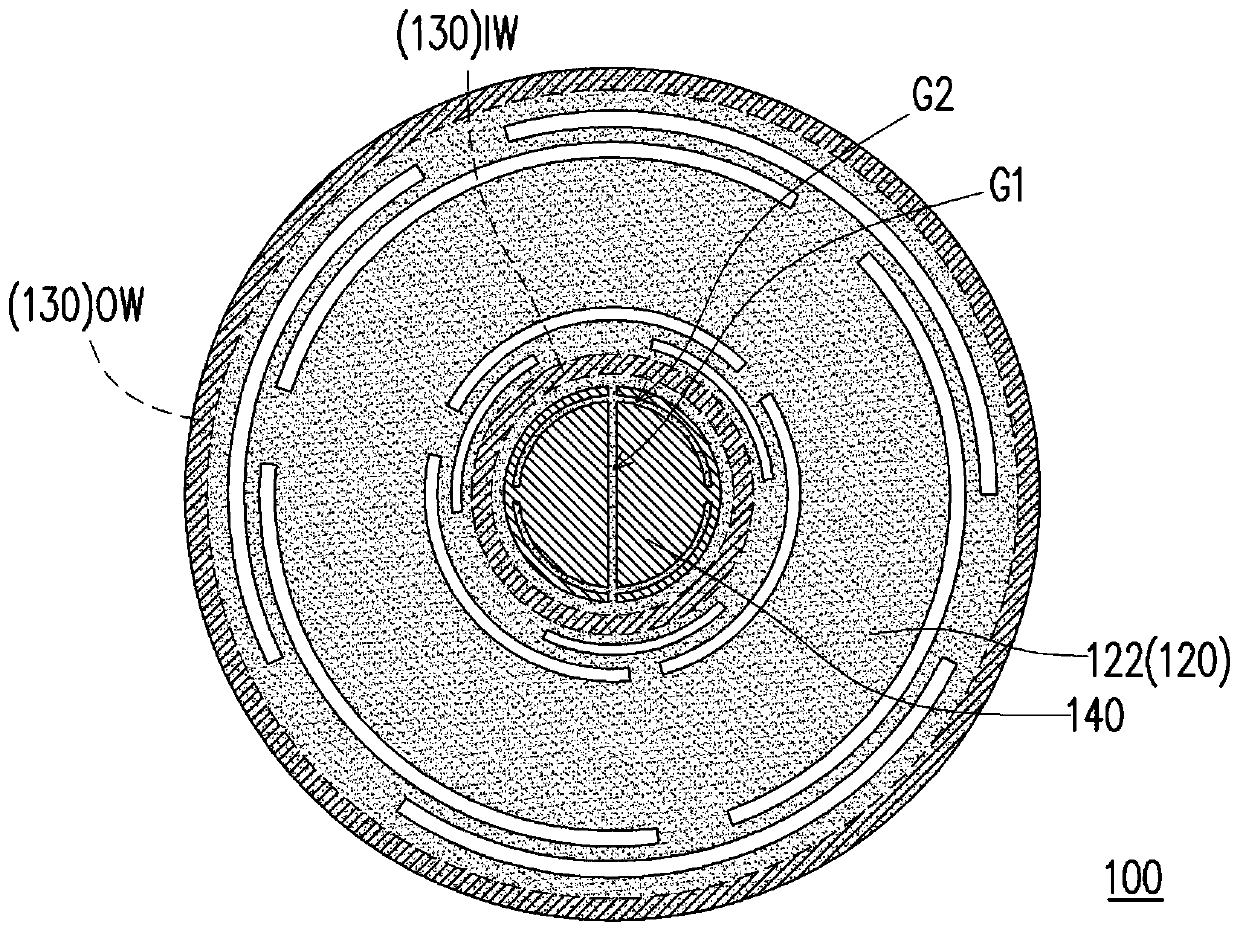
Owner:MERRY ELECTRONICS (SHENZHEN) CO LTD
Ball bearing switch
ActiveCN101079621AReduce the probability of misoperationImprove usage sensitivityElectronic switchingCoupling light guidesBall bearingMechanical engineering
The invention discloses a ball switcher, which comprises the following parts: base, a seal launcher and a receiver assembled in the seal container jacketed in the base to mate mutually, seal container jacketed in the base to contain ball and bearing unit, lid to cover the base, wherein the inner cylinder contains a basic wall and optical inlet hole through the basic wall to face the straight communicating path; the inner lid concludes a cap, a self-sealing moulding projection and optical outlet hole through the projection to face the straight communicating path; the ball rolls between the baffling position and the separating position of straight communicating path. The invention can prevent ball not lying at the baffling position, which can reduce the error movement generating rate.
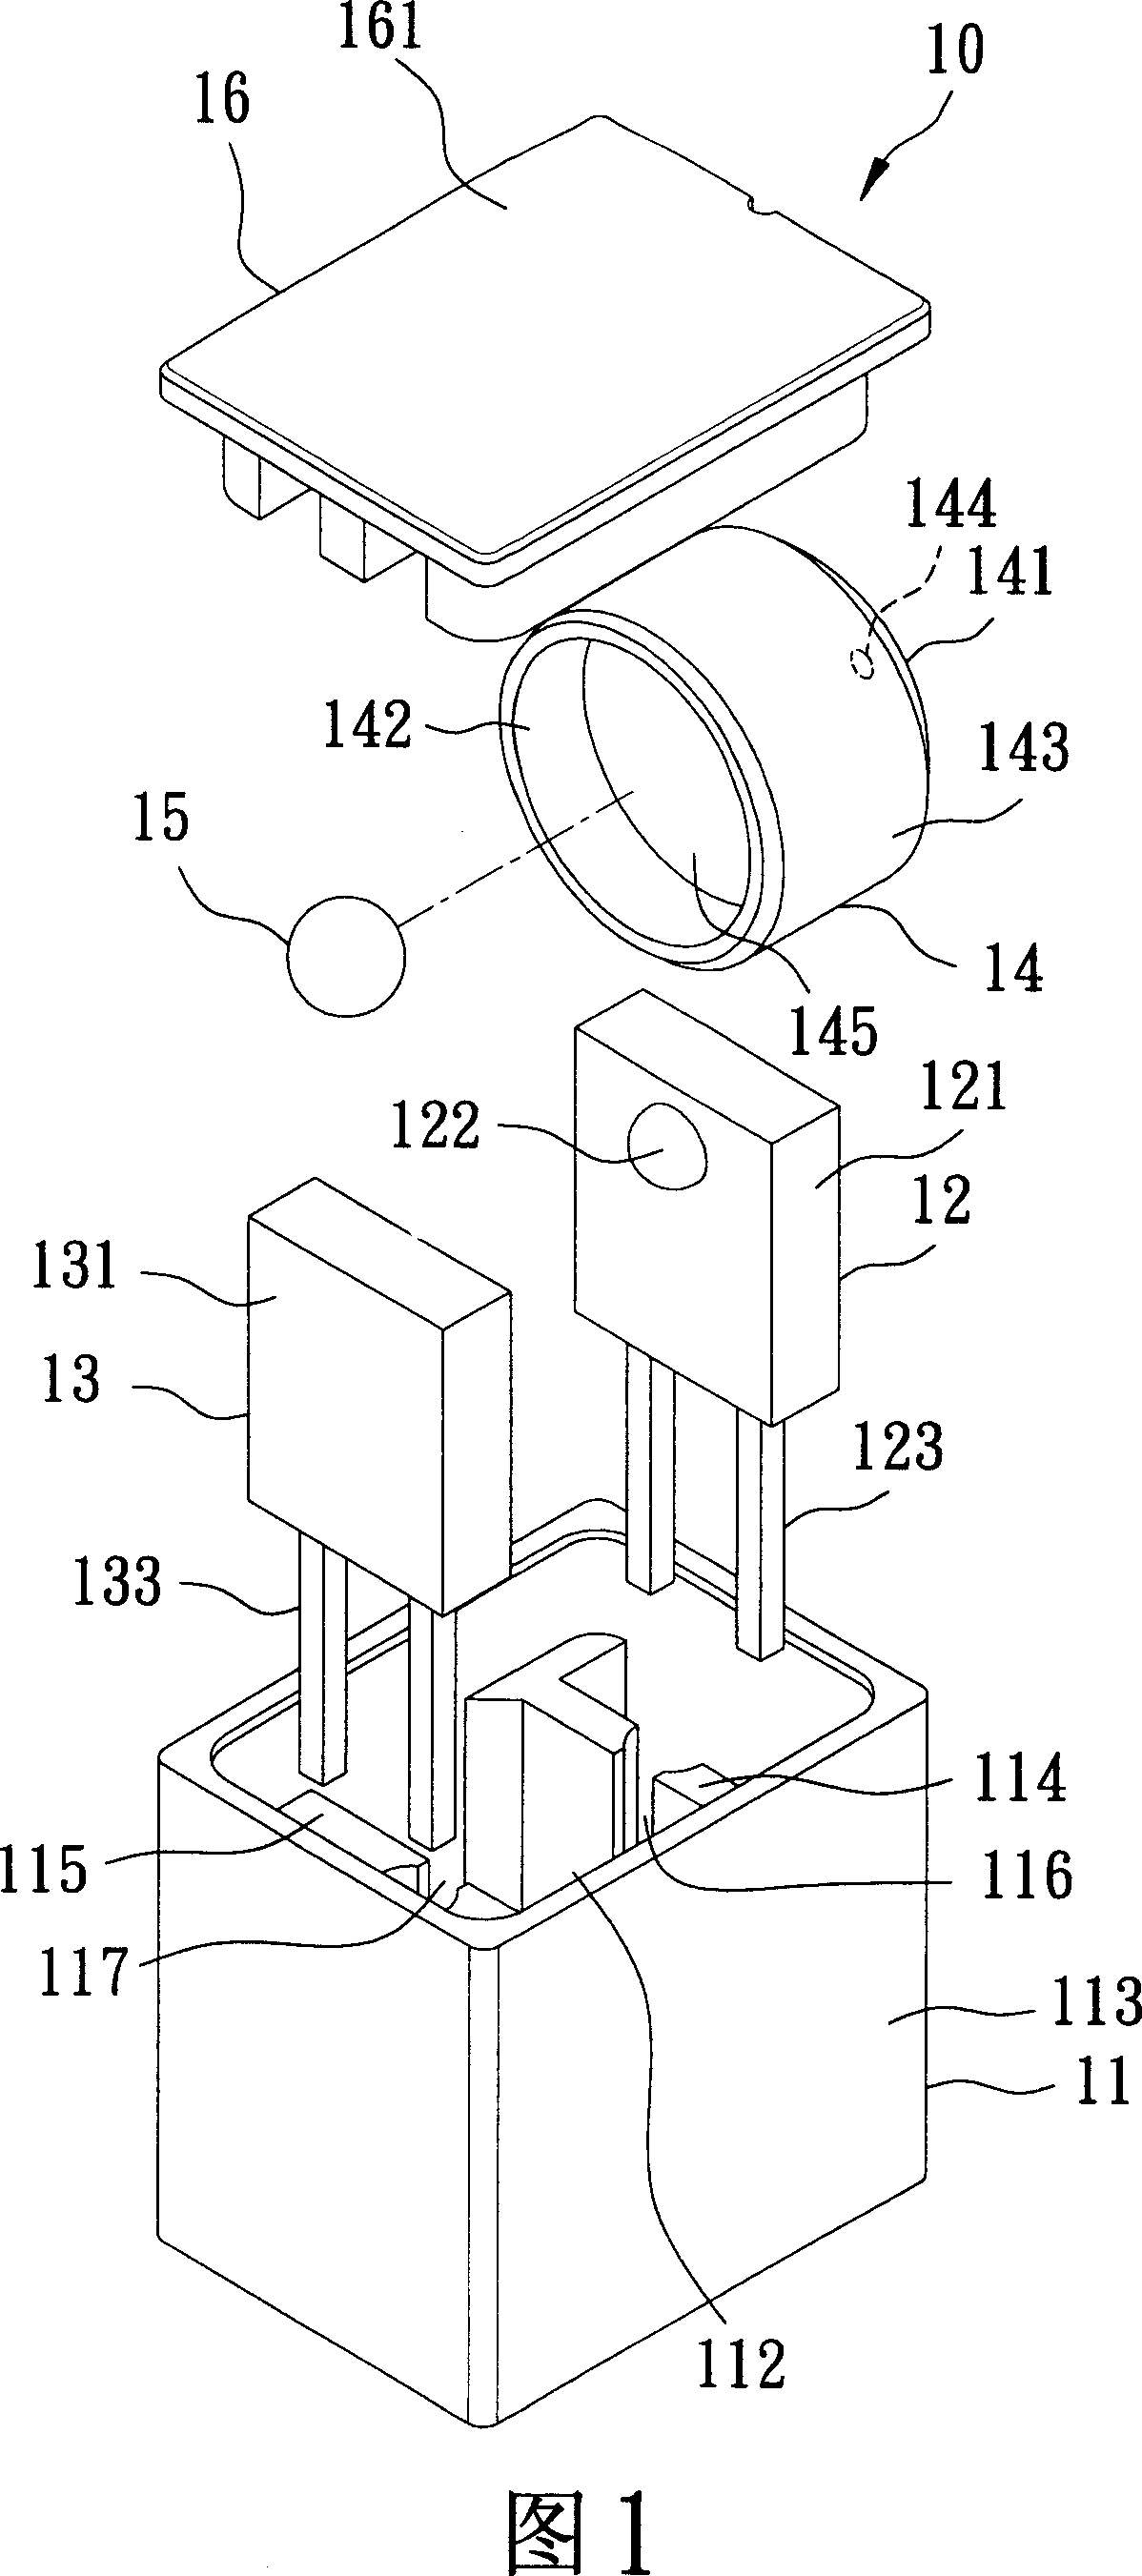
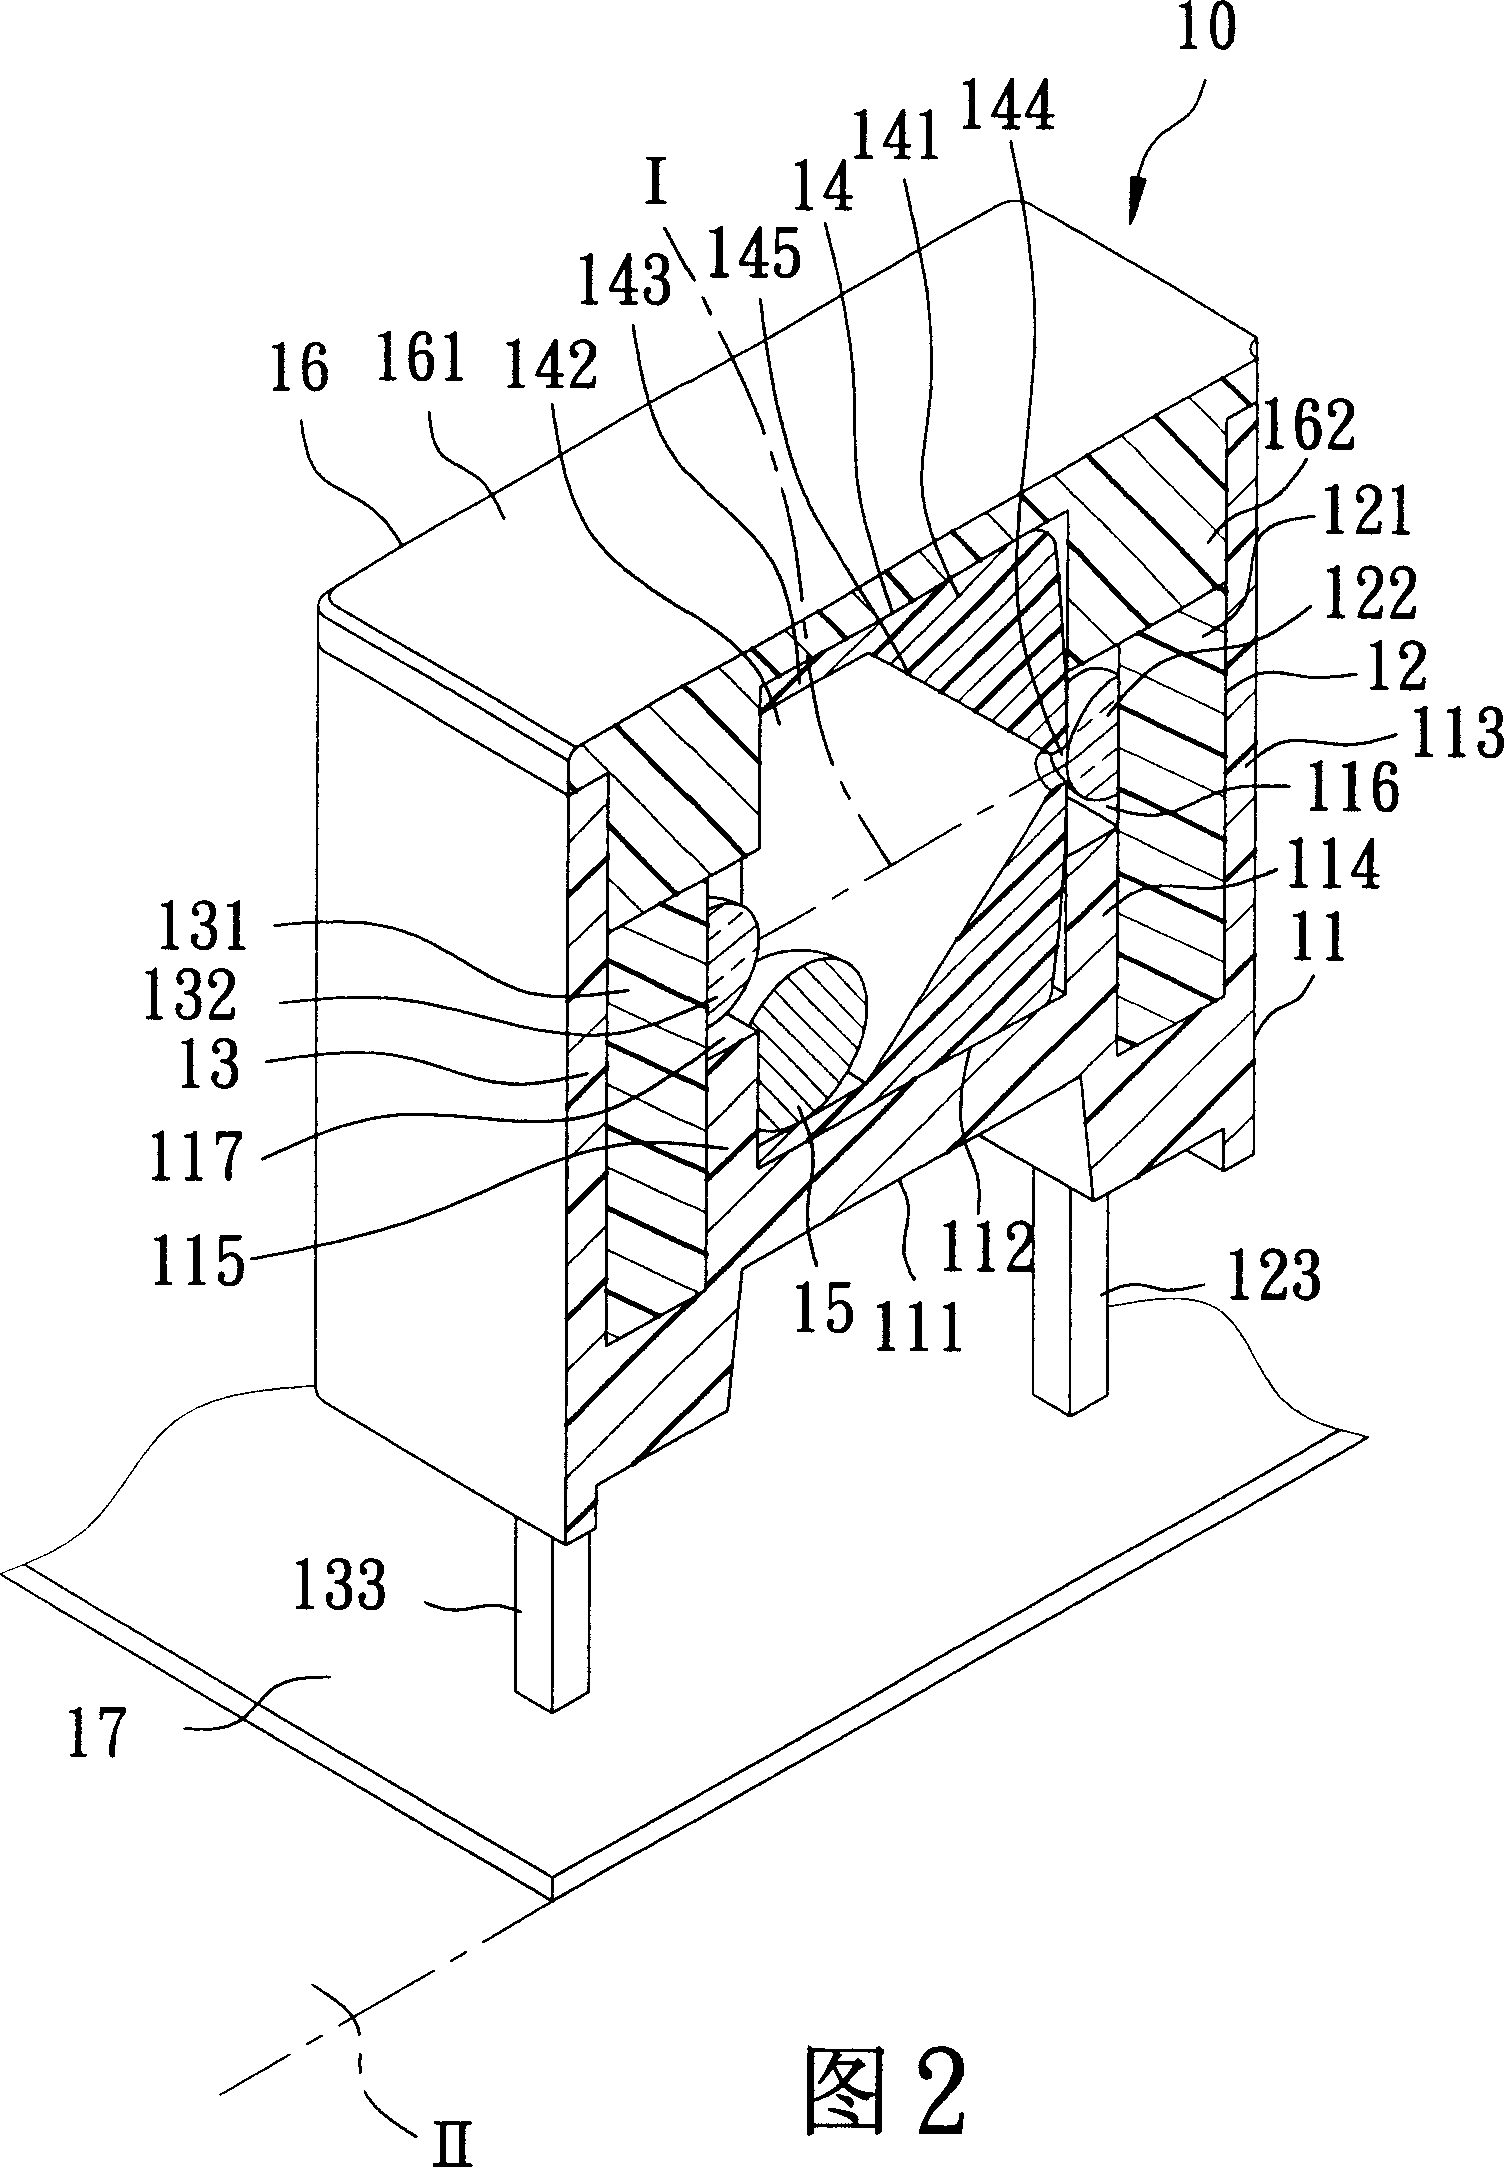
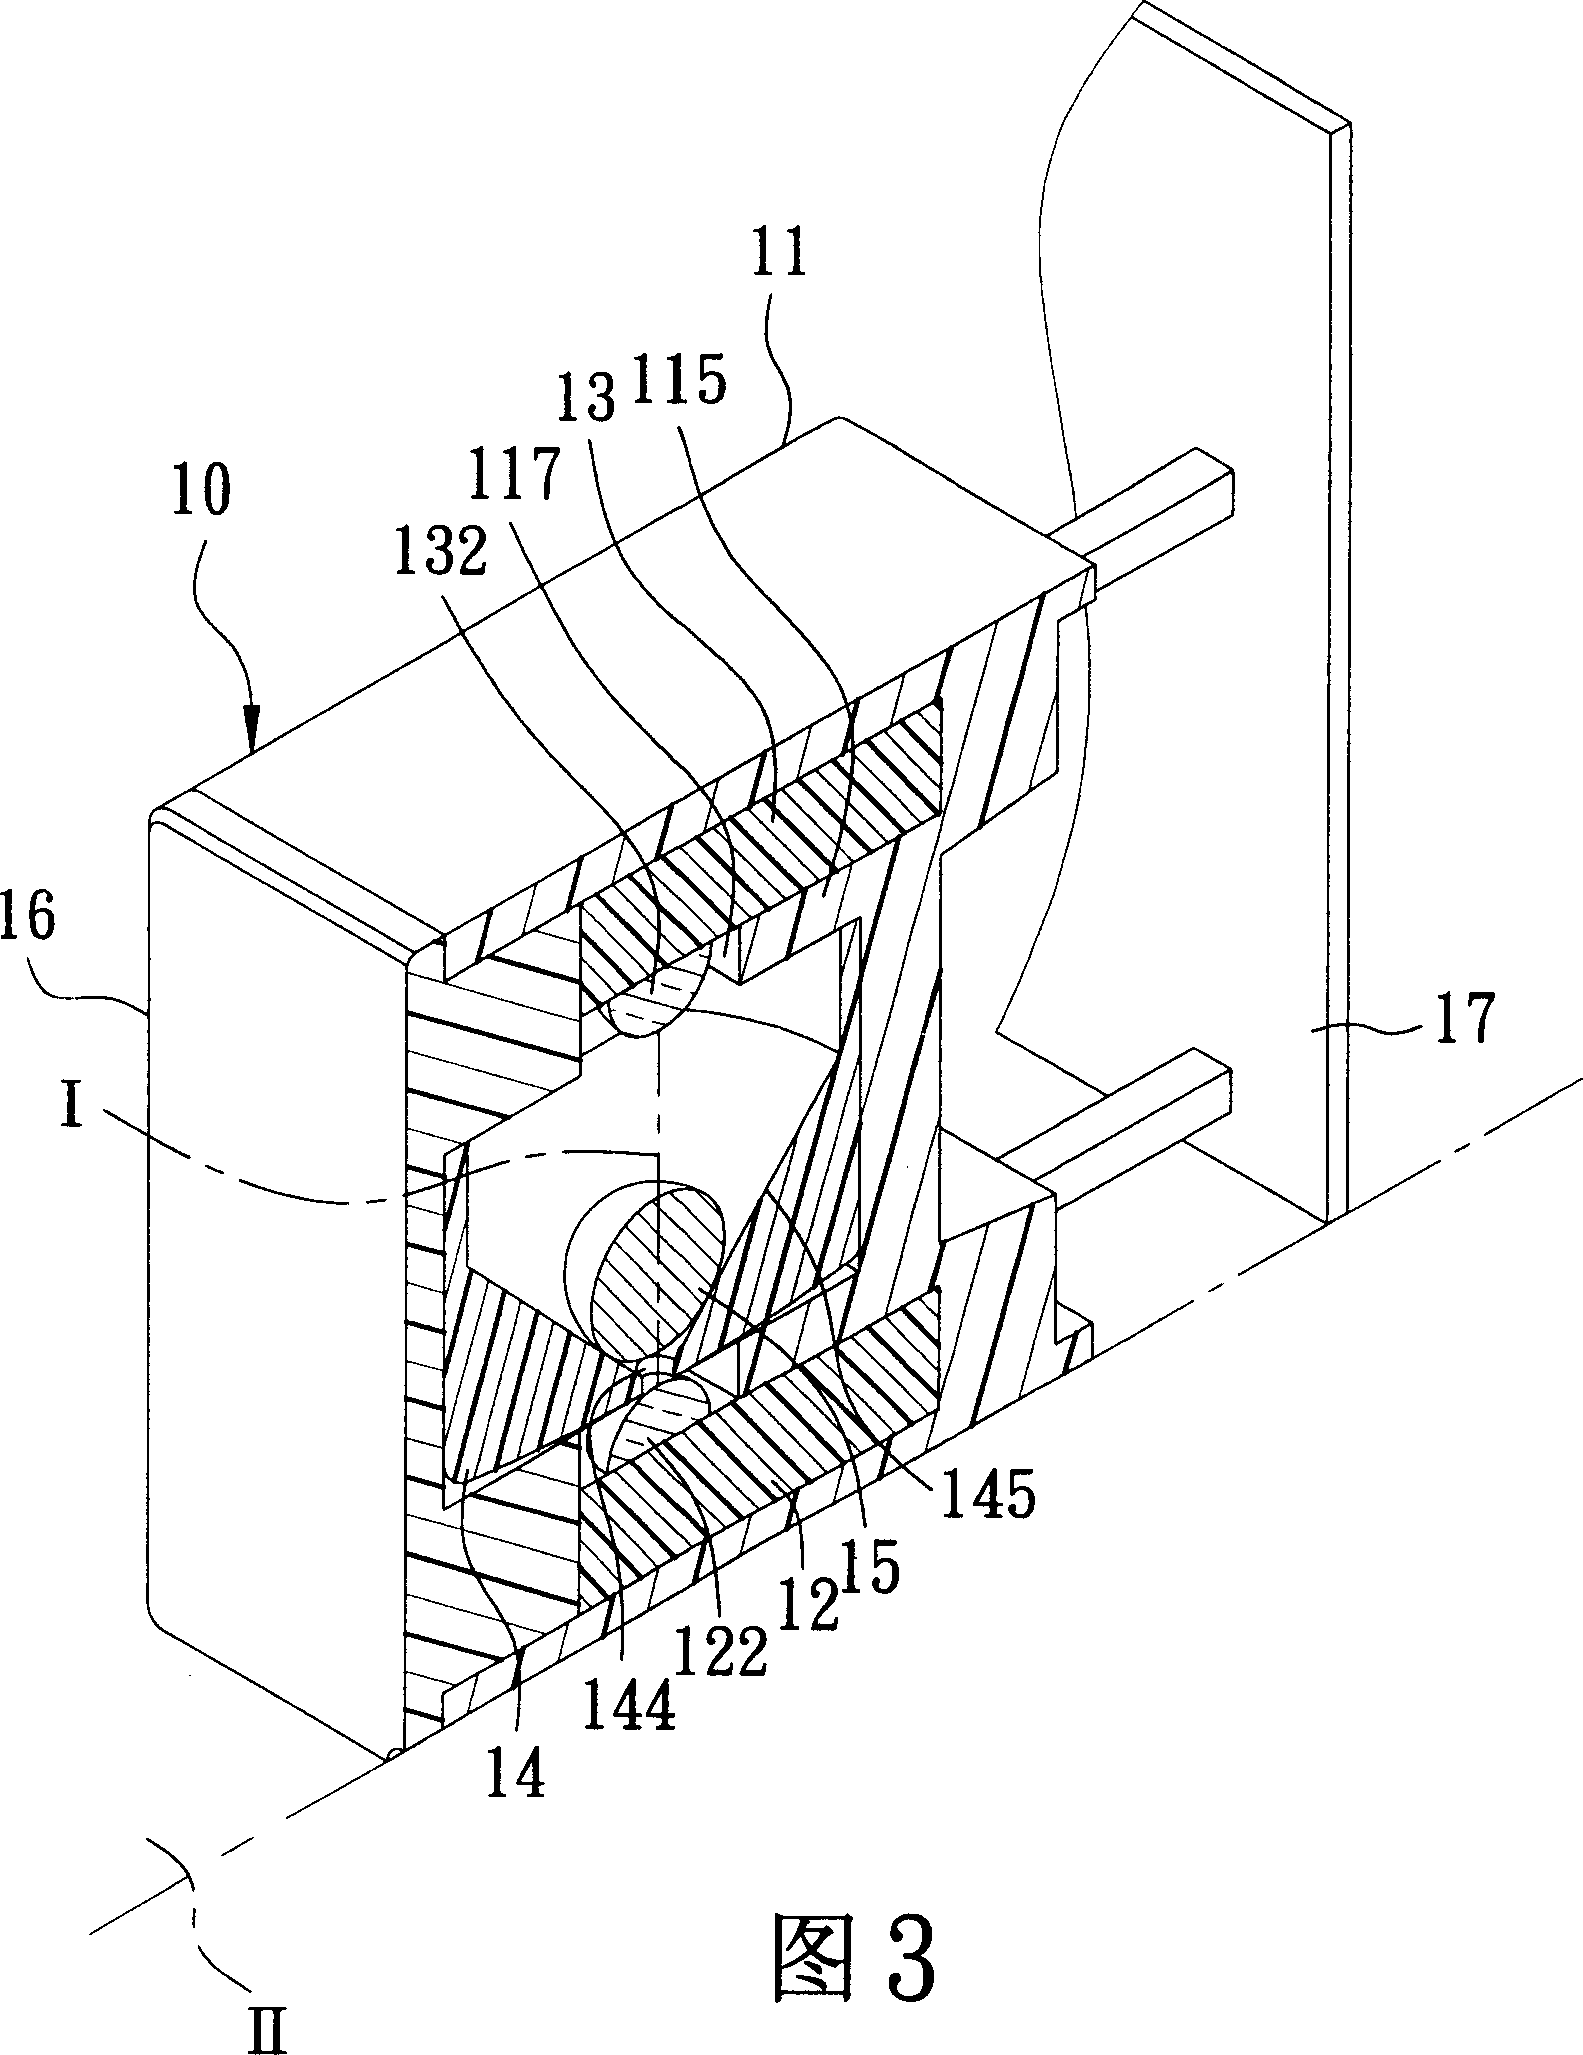
Owner:ONCQUE CORP
Electrochemical sensor based on photoelectric coupling effect, and preparation method thereof
ActiveCN108195907ANo shortening of service lifeImprove usage sensitivityMaterial electrochemical variablesElectrochemical gas sensorIron oxide
The invention discloses an electrochemical sensor based on a photoelectric coupling effect, and a preparation method thereof. The electrochemical sensor comprises an YSZ solid electrolyte layer, a heating sheet, a reference electrode and three sensitive electrodes, wherein the three sensitive electrodes respectively are a first sensitive electrode, a second sensitive electrode and a third sensitive electrode, the first sensitive electrode is made of zinc oxide, the second sensitive electrode is made of the mixture of zinc oxide and iron oxide, the mass of the iron oxide is 20% of the mass of the zinc oxide in the mixture, the third sensitive electrode is made of the mixture of zinc oxide and cerium oxide, the mass of the cerium oxide is 30% of the mass of the zinc oxide in the mixture, andthe reference electrode is made of manganese dioxide. According to the present invention, the electrochemical sensor is prepared by using the easily-available materials on the basis of the ensuring of no service life shortening, and has the high sensitivity; and the photoelectric coupling effects of the sensors on different gases can be adjusted by illumination so as to achieve the efficient identification on a variety of gases, such that the selectivity is strong.


Owner:QI DIAGNOSTICS LTD
Magnetic flourescent nano material for magnetic-photo sensor and preparation method thereof
InactiveCN101723311BQuick responseImprove the accuracy of useIndividual molecule manipulationInorganic material magnetismQuantum yieldFiber


Owner:WUHAN UNIV OF TECH
Intelligent conveying pipeline capable of displaying pipeline blockage position
ActiveCN113738960AImprove reliabilityRapid positioningGeneral water supply conservationPipeline systemsStructural engineeringMechanical engineering
The invention discloses an intelligent conveying pipeline capable of displaying a pipeline blockage position. The intelligent conveying pipeline capable of displaying the pipeline blockage position comprises an inner-layer pipe, a steel wire reinforcing layer, a compression-resistant layer, an optical fiber ribbon layer and an outer-layer pipe which are sequentially arranged from inside to outside, wherein the steel wire reinforcing layer and the compression-resistant layer are both single-layer or multi-layer. According to the intelligent conveying pipeline capable of displaying the pipeline blockage position provided by the invention, the optical fiber ribbon co-extrusion mode is adopted, an optical fiber ribbon prepared in advance is ingeniously combined with a gathering and transportation pipeline, and the pipeline blockage position is judged according to the temperature change of the gathering and transportation pipeline. When blockage occurs, the blockage position can be quickly positioned, operation can be recovered only through fixed-point excavation and simple repair, and the intelligent conveying pipeline capable of displaying the pipeline blockage position is simple and efficient. In addition, the optical fiber is high in reliability, can work in a severe environment, is not influenced by temperature, humidity and pH value, is durable, does not need to shield an electromagnetic field during use, is high in use sensitivity, and is convenient to detect.

Owner:LINHAI WEIXING NEW BUILDING MATERIALS CO LTD
Expandable and reconfigurable multi-level sensing flexible robot skin
ActiveCN114536355AImprove detection resolutionReduce spatial resolutionEnergy saving control techniquesManipulatorManufacturing technologyControl cell
The invention discloses an expandable and reconfigurable multi-level sensing flexible robot skin. The flexible sensing light-emitting array is connected with the data reading and processing unit and the micro-control unit. The micro-control unit is connected with the flexible robot skin expansion connection interface and the flexible robot skin data output interface. The flexible sensing light-emitting array realizes a multi-level sensing function by switching an approaching sensing mode and a pressure sensing mode, and the micro-control unit realizes sensing mode switching and reconstruction of the flexible sensing light-emitting array by controlling the data reading and processing unit. The flexible robot skin has the functions of approaching sensing, pressure sensing, detection result in-situ visualization, skin structure expandability, flexible approaching sensing unit reconfiguration and the like. Compared with a traditional single-mode resistive pressure sensor and a capacitive approaching sensor, the sensor combines the advantages of the two types of sensors, and has the characteristics of high sensitivity, simple device structure, simple manufacturing process, high spatial resolution and the like.
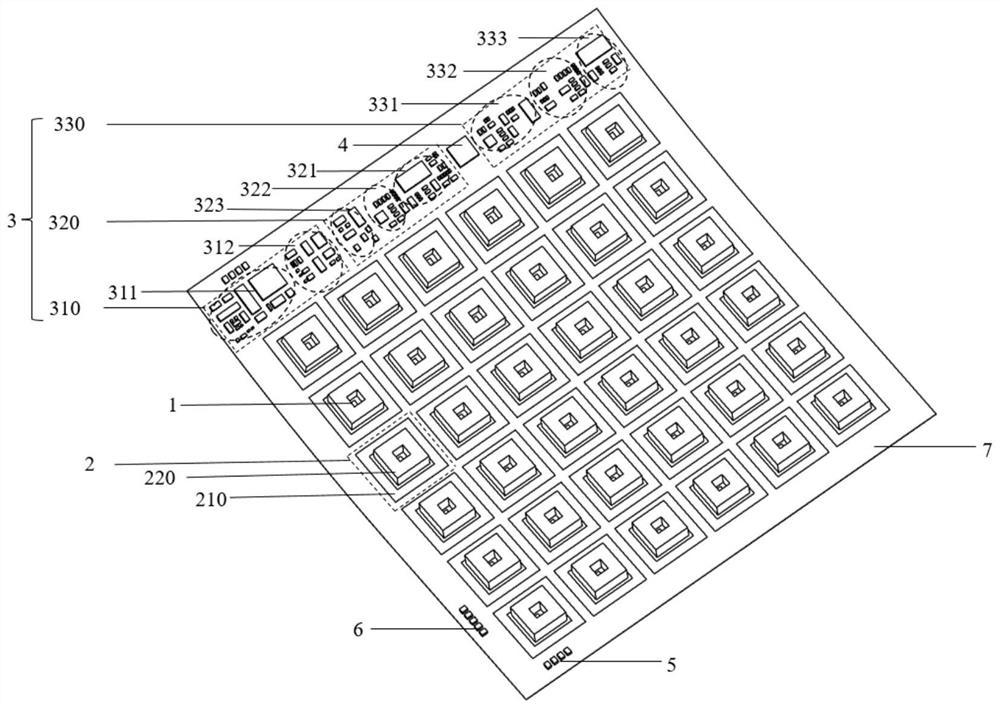
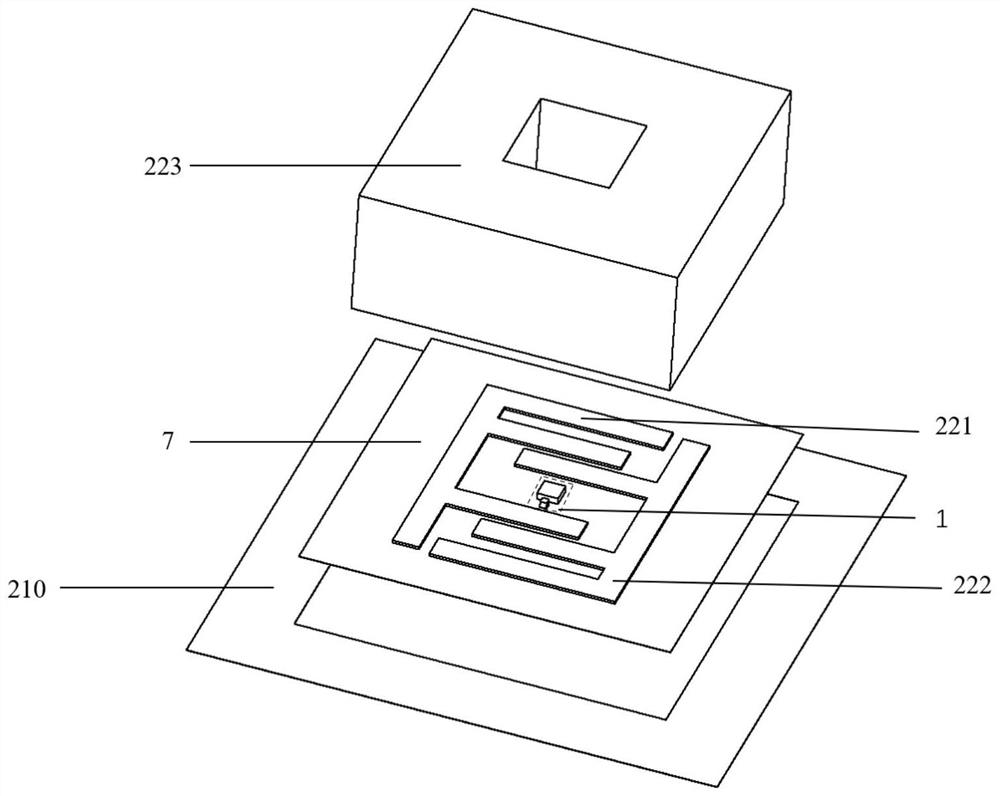
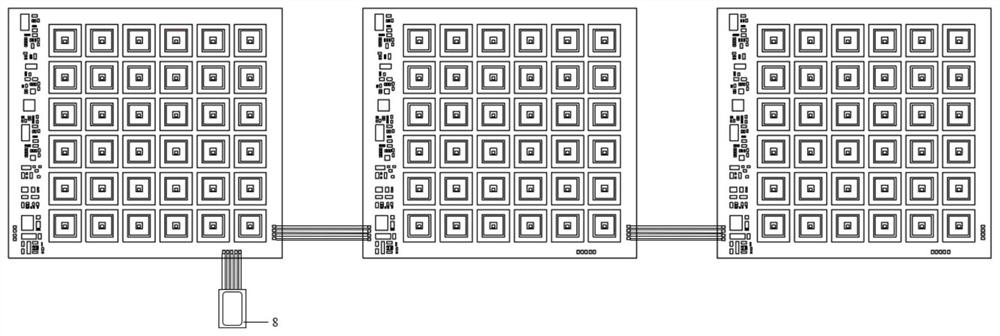
Owner:ZHEJIANG UNIV
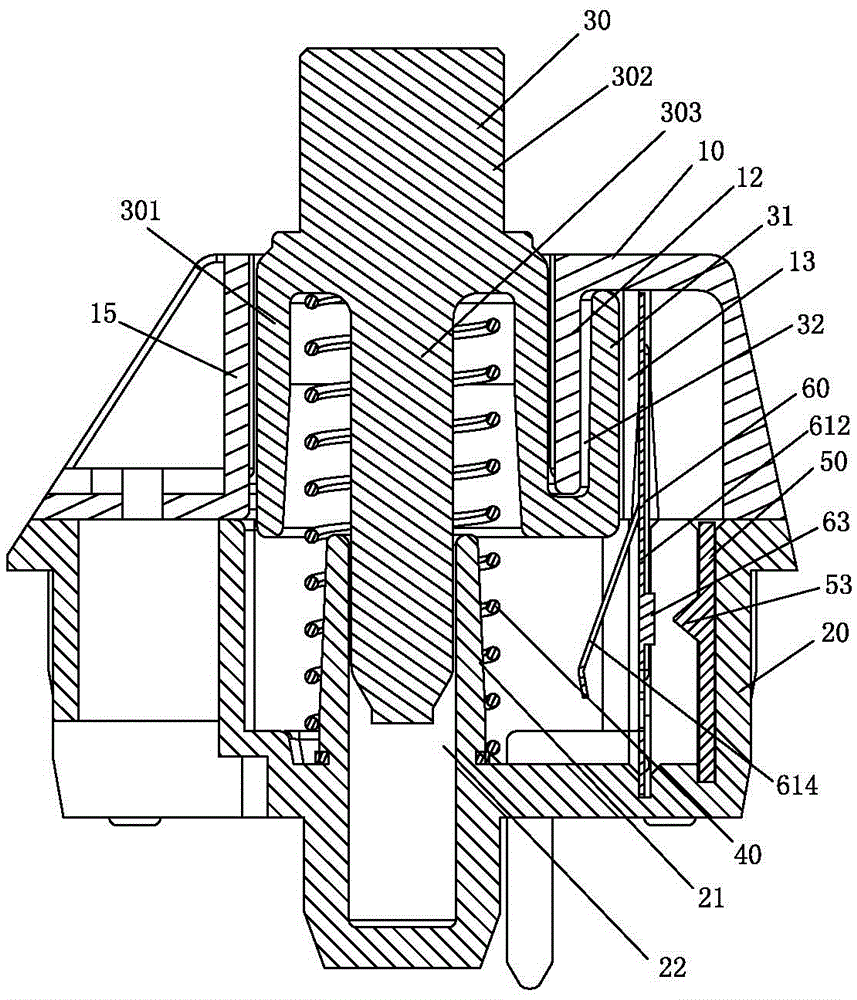
Dustproof mechanical keyboard switch capable of being automatically assembled easily and assembly method thereof
ActiveCN105938771AFeel goodImprove soundEmergency casingsElectric switchesEngineeringMechanical engineering
The invention discloses a dustproof mechanical keyboard switch capable of being automatically assembled easily and an assembly method thereof. The dustproof mechanical keyboard switch comprises an upper cover, a base body, a guide core, a reset spring, a static plate and a movable spring plate, wherein the upper cover is arranged on the base body; the upper cover and the base body are enclosed to form an accommodating space; a through hole which runs through the accommodating space is formed in the upper cover; the reset spring is arranged in the accommodating space; the guide core is connected to the reset spring and can extend out of the through hole in a sliding manner; the movable spring plate is driven by the guide core to be in contact with the static plate or to be separated from the static plate; the guide core and the upper cover are in folded and staggered arrangement through a first dust-break wall and a second dust-break wall to effectively prevent external dust from entering the inside of the keyboard switch; and the static plate and the movable spring plate are tightly embedded into a first mounting groove and a second mounting groove respectively to assemble and fix the static plate and the movable spring plate on the base body. Therefore, the automated assembling capacity of a product is improved under the premise of ensuring relatively good dustproof property; the assembly efficiency and the assembly quality are improved; and the product stability is strengthened.
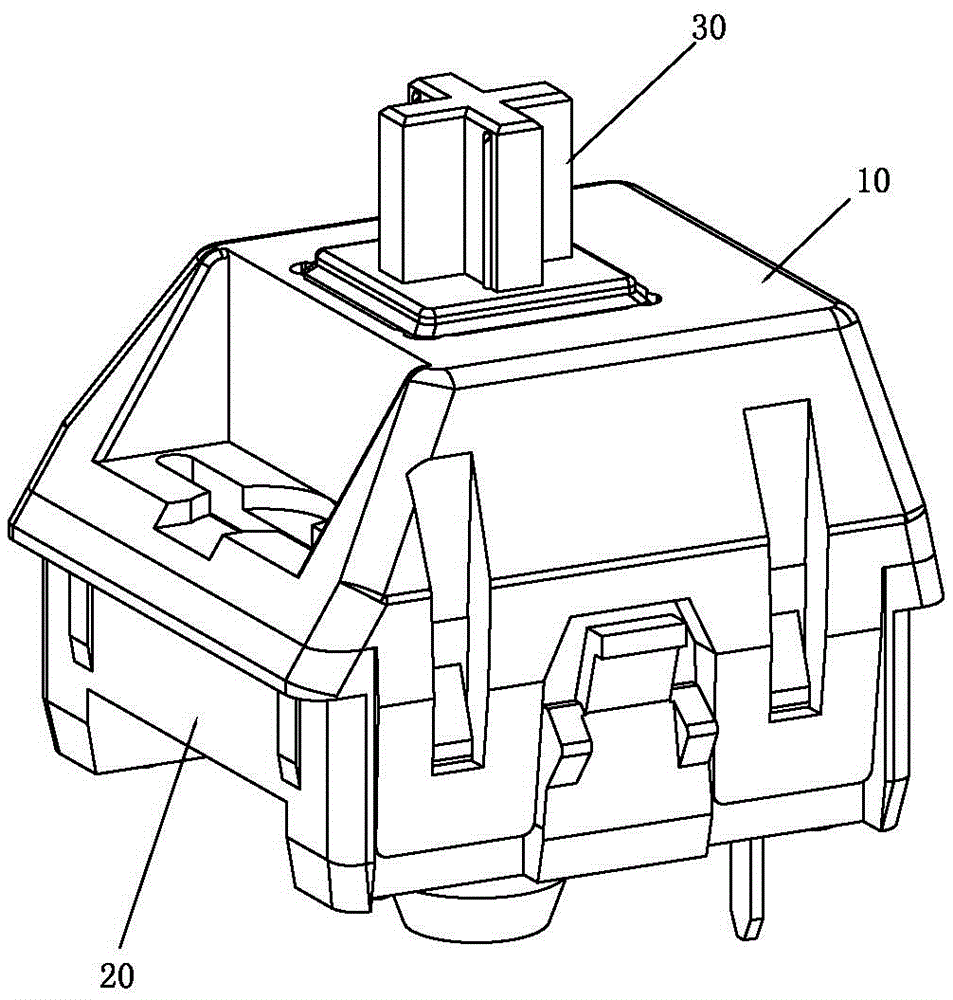
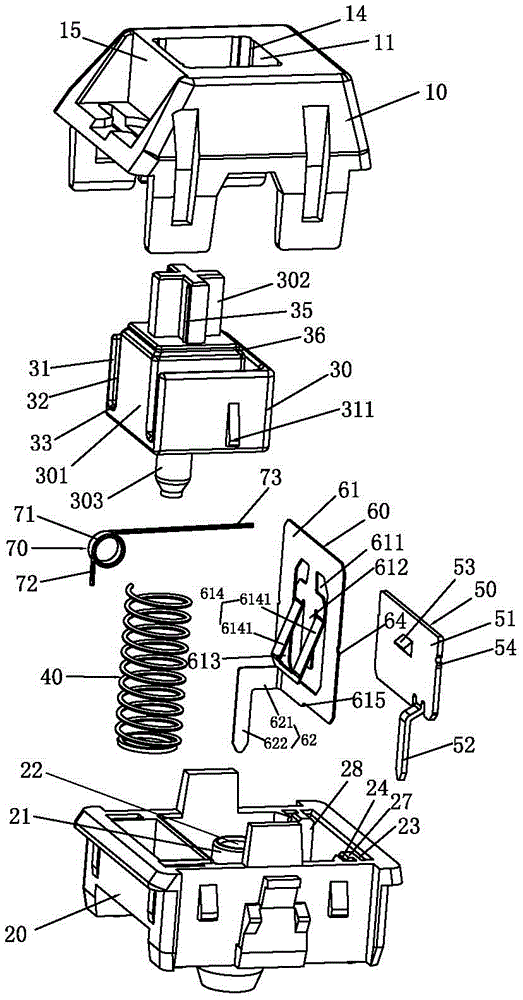
Owner:浙江长风电子有限公司
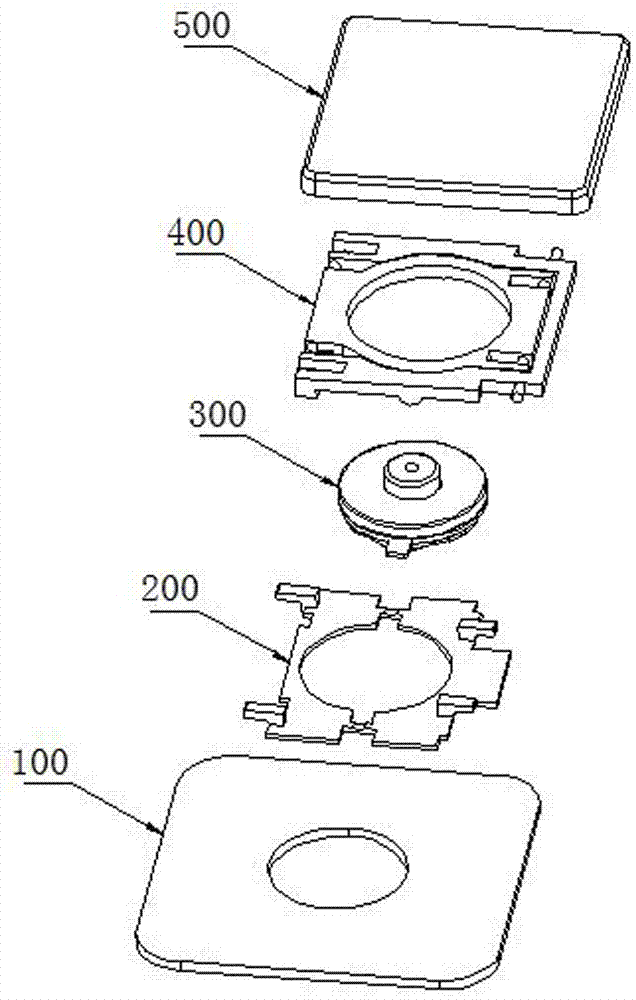
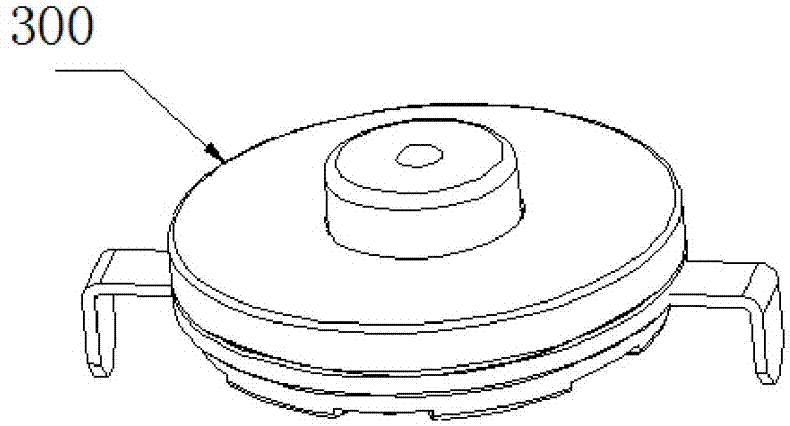
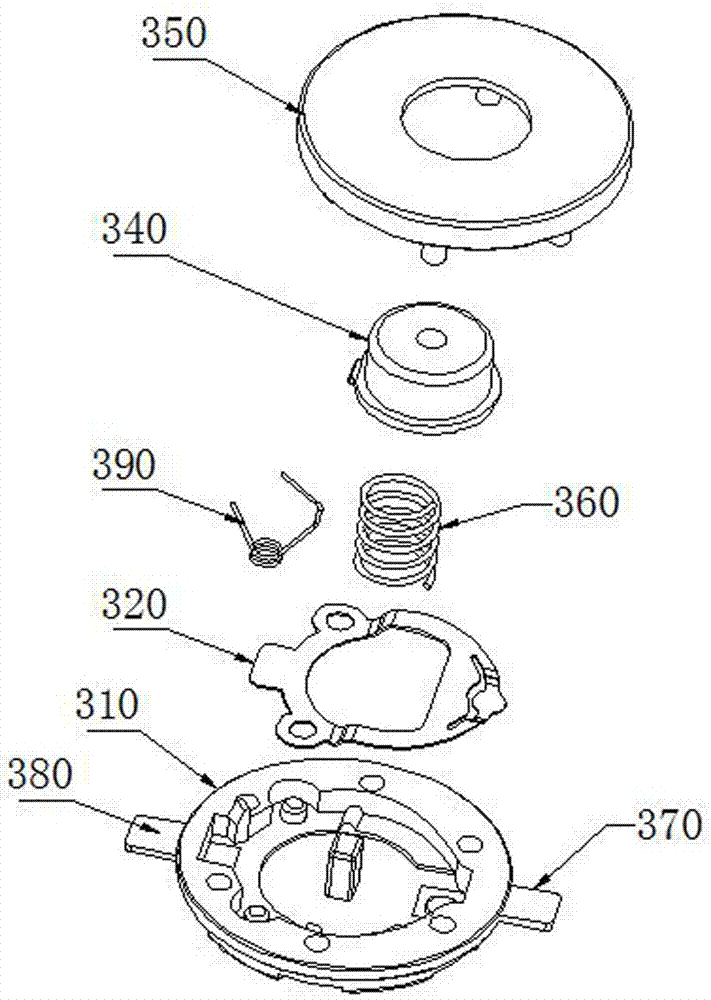
Thin switch
ActiveCN107393756ACheap compositionSimple structureEmergency casingsElectric switchesSurface coverEngineering
The invention discloses a thin switch, comprising a surface cover, a press part, a base, a sounding piece and a contact spring, wherein the surface cover is provided with a press hole in the center; the press part is mounted in the press hole of the surface cover; the base is connected with the surface cover by riveting, the base is provided with a contact spring accommodating groove in the center, and the circumference of the contact spring accommodating groove is a base groove wall; the sounding piece is located on the base groove wall; the contact spring is horizontally arranged in the contact spring accommodating groove, the top of the contact spring is lower than the upper surface of the base, and the conducting part of the contact spring is located on the side of the base. The thin switch has the advantages of simple structure, low thickness, good user experience and the like.
Owner:刘二军
Thin keyboard
ActiveCN107393757ACheap compositionSimple structureEmergency casingsElectric switchesEngineeringSurface cover
The invention discloses a thin keyboard, comprising a bottom plate assembly, a plurality of keys and a thin switch, wherein the bottom plate assembly comprises a circuit board and a support plate; the keys are arranged on the bottom plate, each key is provided with a key cap and a scissor pin above the key cap in sequence from top to bottom, the upper part of the scissor pin is in contact connection with the key cap, and the lower part of the scissor pin is connected with the support plate; the thin switch is connected with the circuit board, and comprises a surface cover, a press part, a base, a sounding piece and a contact spring, wherein the surface cover is provided with a press hole in the center; the press part is mounted in the press hole of the surface cover; the base is connected with the surface cover by riveting, the base is provided with a contact spring accommodating groove in the center, and the circumference of the contact spring accommodating groove is a base groove wall; the sounding piece is located on the base groove wall; the contact spring is horizontally arranged in the contact spring accommodating groove, the top of the contact spring is lower than the upper surface of the base, and the conducting part of the contact spring is located on the side of the base. The thin keyboard has the advantages of simple structure, low thickness, good user experience and the like.


Owner:刘二军
Capacitive type light touch switch, switching circuit and key system
ActiveCN103762968APreserve finger touchExtended service lifeElectronic switchingLight touchCapacitance
The invention discloses a capacitive type light touch switch. The capacitive type light touch switch comprises an upper electrode slice, a lower electrode slice, a button and an insulation spacer, wherein the upper electrode slice and the lower electrode slice are arranged oppositely; the button is arranged on the upper electrode slice; the insulation spacer is arranged between the upper electrode slice and the lower electrode slice. After the upper electrode slice and the lower electrode slice are powered on, the button pushes the upper electrode slice to move or elastically deform towards the lower electrode slice according to the pressed situation of the button, so that the distance between the upper electrode slice and the lower electrode slice is changed, and then the capacitance between the upper electrode slice and the lower electrode slice is changed. The invention further discloses a switching circuit and a key system. A switching contact is not needed in the light touch switch, the finger touch of the light touch switch is reserved, the service life of the light touch switch is prolonged, the flexibility of the light touch switch is improved, and cost is low.


Owner:SHENZHEN TCL NEW-TECH CO LTD
Multi-axis numerical control mechanical claw based on parallel mechanism
PendingCN113524145ALarge operating rangeImprove usage sensitivityProgramme-controlled manipulatorGripping headsNumerical controlElectric machinery
The invention relates to the field of mechanical claws, in particular to a multi-axis numerical control mechanical claw based on a parallel mechanism. The multi-axis numerical control mechanical claw comprises a grabbing structure, a parallel rotating structure and a packaging shell, wherein the bottom of the parallel rotating structure is rotationally connected with the packaging shell, a mechanical claw angle adjusting cavity is formed in the packaging shell, an angle control structure is arranged in the mechanical claw angle adjusting cavity, and the bottom end of the angle control structure is hinged to the grabbing structure; and the grabbing structure comprises a first fixing plate, a first rotating rod, a second rotating rod, a second fixing plate, a third rotating rod, a clamping plate, fixing rods, a third fixing plate, a first motor 19 and a lead screw 191, and the top ends of the four fixing rods are in threaded connection with the bottom of the third fixing plate. The angle control structure and the rotating structure are arranged at the bottom of the parallel rotating structure, so that the rotating angle of the parallel rotating structure is increased, the mechanical claw can be applied to more working scenes, and the sensitivity of the mechanical claw is effectively improved.
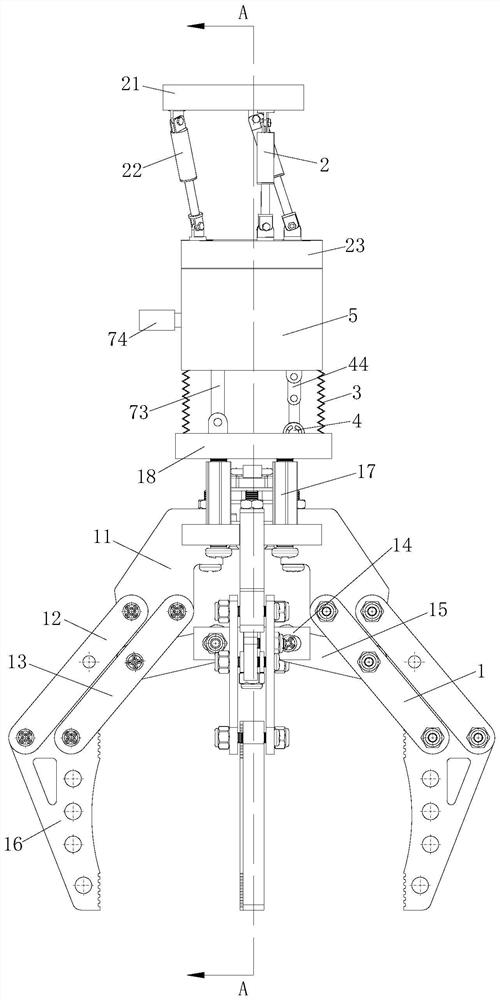
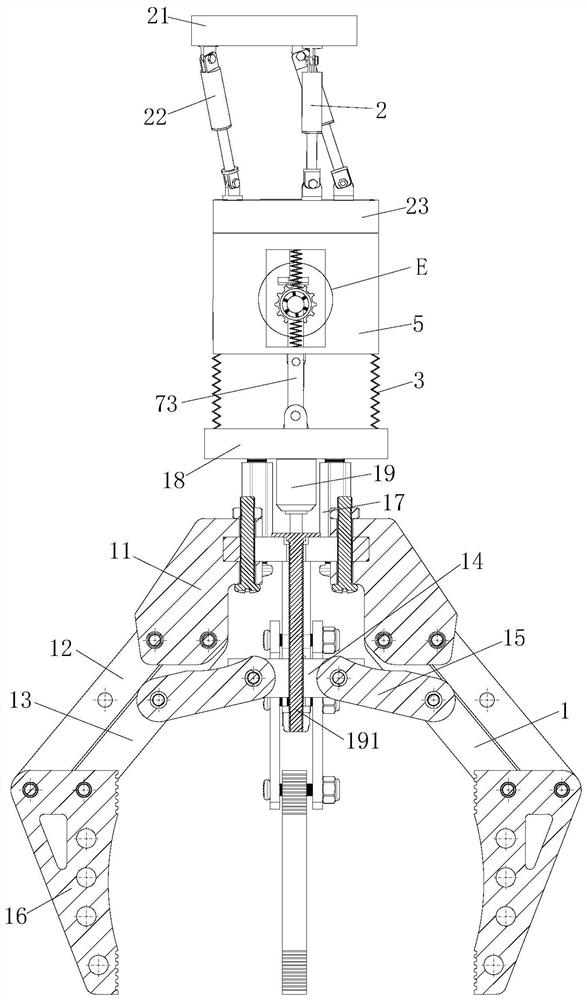
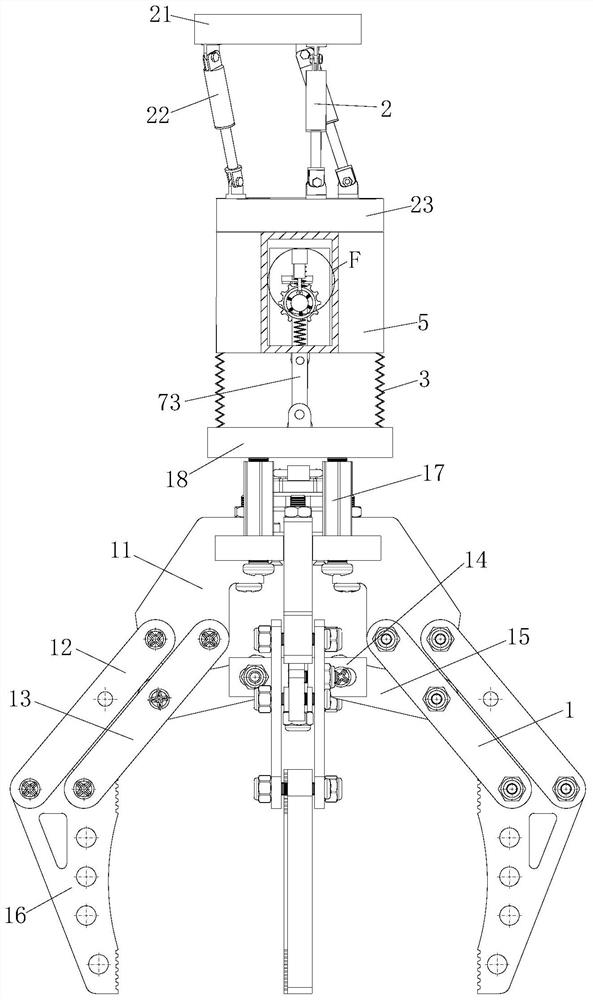
Owner:ANHUI UNIV OF SCI & TECH
Pure-solid-wood digital display device
InactiveCN106773619APrevent digital displayImprove the aesthetics of useElectronic time-piece structural detailsVisual indicationsSolid woodLED display
The invention discloses a pure-solid-wood digital display device which comprises a solid-wood casing, an LED display screen (2) and a main control board (3), wherein the LED display screen and the main control board are arranged in the solid-wood casing. The pure-solid-wood digital display device is characterized in that a groove (6) is formed in the inner side of a front wall of the solid-wood casing, the LED display screen (2) is arranged in the groove (6) with the front side facing inwards, and the thickness of the groove bottom of the groove (6) is 0.2 to 0.5mm. The pure-solid-wood digital display device has the advantages that the solid-wood casing of the thickness has good light transmission when the LED display screen is switched on, the solid-wood casing can prevent numbers on the display screen from being presented when the LED display screen is switched off, and accordingly use attractiveness is improved.


Owner:SUZHOU TAISHUN ELECTRIC APPLIANCE
Terminal printing device protection device with automatically opened and closed protection covers
InactiveCN106183475AAvoid dust accumulationAvoid shockOther printing apparatusMotor driveElectrical and Electronics engineering
The invention relates to a terminal printing device protection device with automatically opened and closed covers. The terminal printing device protection device comprises an integrated shell. The lower portion of the shell is in a rectangular shape. The upper portion of the shell is in a rectangular shape with the thickness smaller than that of the lower portion of the shell. A rectangular paper outlet is formed in the front side face of the lower portion of the shell. A processor is installed at the lower portion of the shell. The processor is connected with a motor drive plate located at the lower portion of the shell. A stepping motor is fixed to each of the left side and the right side of the rear end face of the upper portion of the shell. The stepping motors are connected with the motor drive plate. According to the terminal printing device protection device with the automatic opening and closing cover, the arc shell covers automatically opened and closed are additionally arranged on the integrated terminal protection shell and are automatically closed and opened according to the condition of whether people use the device or not on the field, it is ensured that a touch screen is protected when the device is not used, dust concentration is avoided, unnecessary impacts are avoided, rainwater invasion can also be prevented at ordinary times, the service life of the touch screen is prolonged, and the use sensitivity of the touch screen is improved.


Owner:ANHUI TIANSINU INFORMATION TECH
Magnet plunger pump
InactiveCN104033378BExtended service lifeImprove usage sensitivityPositive displacement pump componentsLiquid fuel engine componentsEngineeringMagnetic shield
A magnet type plunger pump comprises a liquid inlet check valve, a tee joint device, a liquid outlet check valve, a cylinder body, a plunger, a seal ring and an eccentric wheel. An annular hollow permanent magnet of the cylinder body is arranged at a liquid access port of the cylinder body, and a hollow magnetic shield of the cylinder body is arranged between the cylinder body and the annular hollow permanent magnet of the cylinder body; an annular solid permanent magnet of the plunger is arranged at the inner end of the plunger, and a concave magnetic shield of the plunger is arranged between the plunger and the annular solid permanent magnet of the plunger; the annular solid permanent magnet of the plunger and the annular hollow permanent magnet of the cylinder body are arranged in opposite and repel mutually; the liquid inlet check valve and the liquid outlet check valve are both magnet type check valves. The magnet type plunger pump has the advantages that since reset springs in existing plunger pumps are replaced by the annular solid permanent magnet of the plunger and the annular hollow permanent magnet of the cylinder body which are arranged in opposite, service life of the plunger pump is remarkably prolonged, and flexibility of the plunger pump is evidently improved.
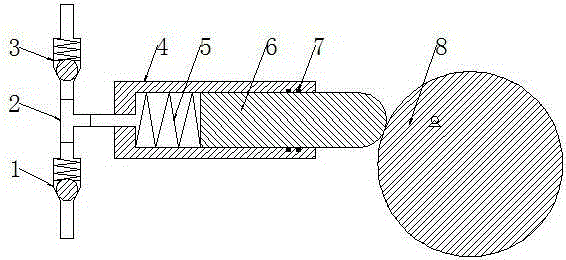
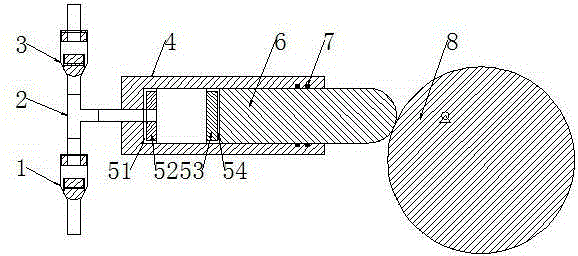
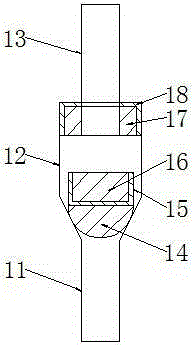
Owner:吉林省东元精密机械有限公司
Bearing pedestal convenient to install
InactiveCN107559334AImprove interoperabilityInteroperability is strongBearing unit rigid supportFixed bearingArchitectural engineering
The invention discloses an easy-to-install bearing seat, which comprises a mounting plate, a bearing base and a bearing casing. The two sets of bearing bases are fixed in the middle of the bearing housing, the inner wall of the bearing housing is provided with steel balls, the outer wall of the steel ball is covered with a cage, and the center of the steel ball is covered with a bearing inner wall The inner and outer walls of the inner sleeve of the bearing are coated with a layer of rubber pad, and the inner fixed sleeve of the rubber pad has a bearing, and the bearing base is fixed with the mounting plate by small-diameter bolts; the easy-to-install bearing Seat, by setting a movable bearing seat on the mounting plate, when the bearing is installed, it can be fixed according to the position of the bearing, which improves the mutual cooperation between the bearing and the bearing seat, and has strong flexibility, thus reducing both The degree of wear between them improves work efficiency and meets production needs.


Owner:响水县冠龙轴承座制造有限公司
Dual-camera scanning gun and scanning method thereof
ActiveCN107111737BShorten the timeImprove usage sensitivitySensing by electromagnetic radiationRadiologyImage pair
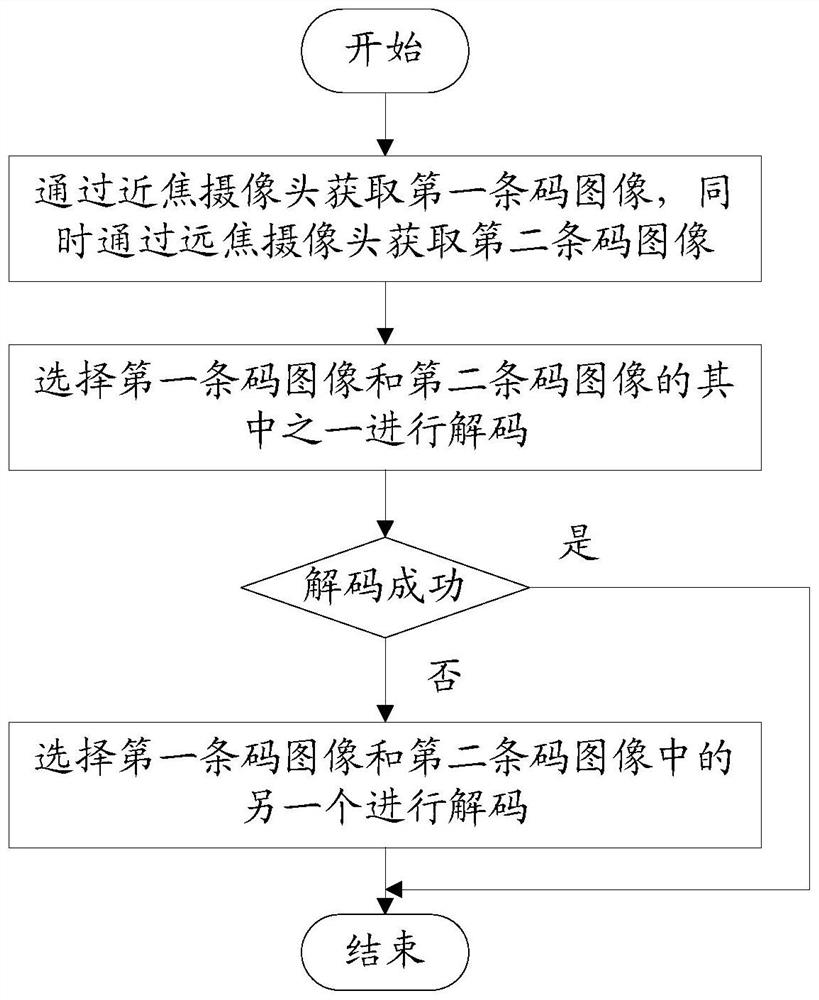
The present invention provides a dual-camera scanning gun and a scanning method for the dual-camera scanning gun, which include a casing, a near-focus camera and a far-focus camera. The casing is provided with a scanning window, and the near-focus camera and the far-focus camera are installed at the scan window. The method is as follows: acquiring the first barcode image through a close-focus camera, and simultaneously acquiring the second barcode image through a far-focus camera; and decoding the first barcode image and / or the second barcode image. The barcode image is obtained by the near-focus camera and the far-focus camera with different depths of field, and the barcode image is decoded to expand the use range of the scanning gun, reduce the time of manual adjustment of the scanning gun, reduce the scanning time of the scanning gun, and improve the scanning sensitivity .
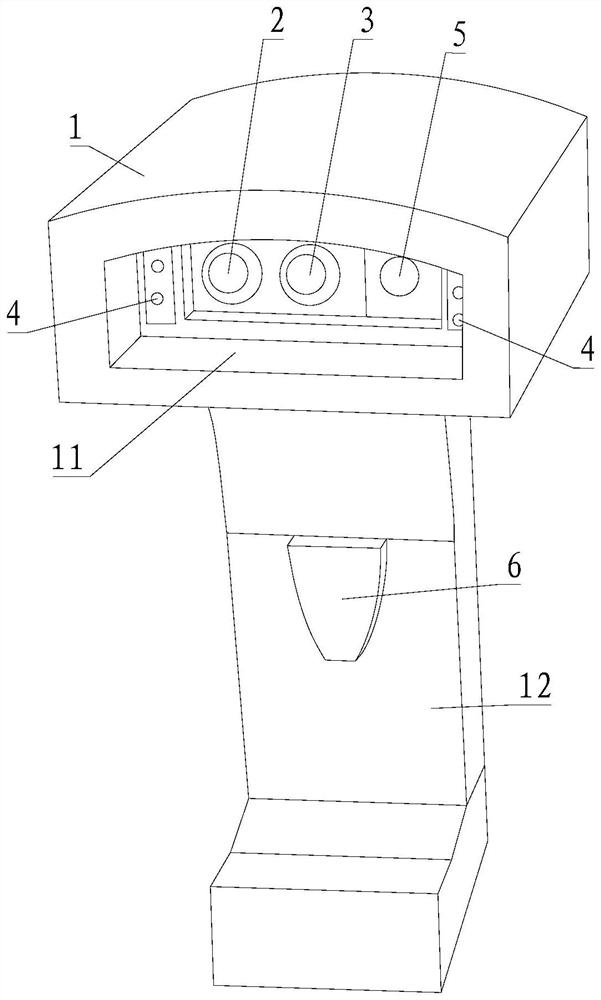
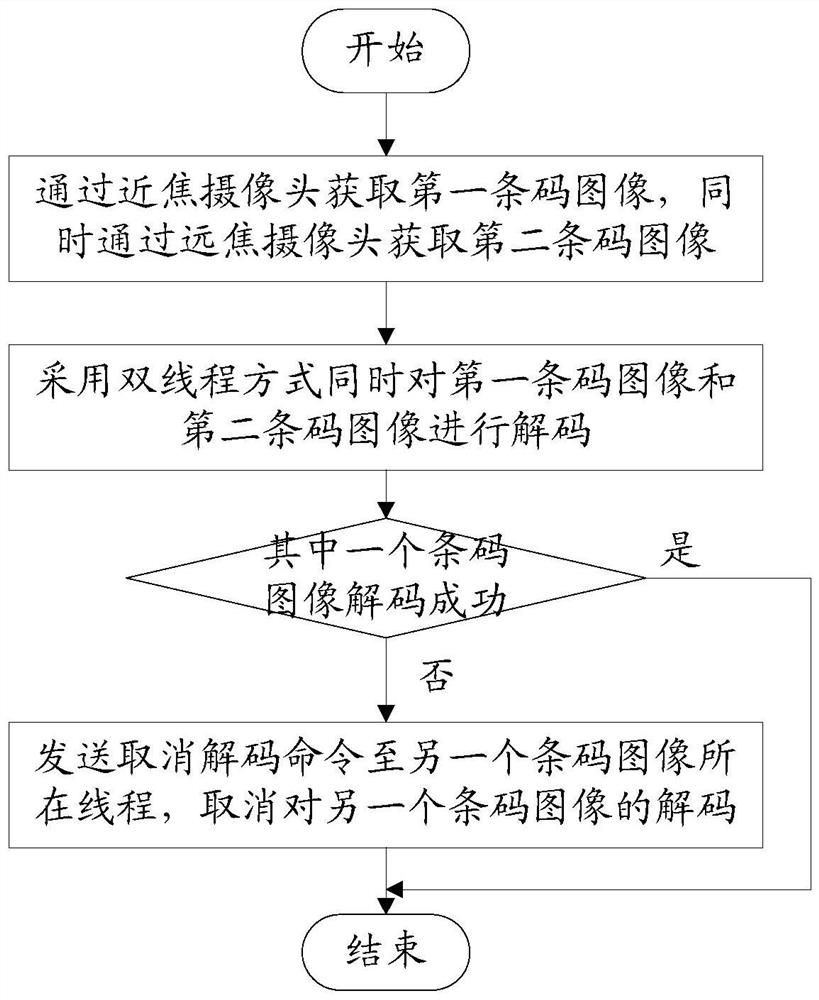
Owner:FUJIAN LANDI COMML EQUIP CO LTD
An electrical timing connection device for building construction
ActiveCN118658739Baffecting workEffective cleaning and removalElectromagnetic relay detailsContactsAlcohol ethylContact failure
The invention discloses an electrical timing connection device for building construction, and relates to the technical field of connection devices, including a time-controlled switch housing and a rear cover plate, wherein a relay is arranged in the time-controlled switch housing, an armature is arranged in the relay, a movable contact plate is arranged on the armature, a normally closed contact plate and a normally open contact plate are arranged in the relay, and a rectangular hole is opened on the relay. The invention arranges a wedge block and a connection box in the time-controlled switch housing, matches the wedge block and the connection box, and then delivers a solvent such as alcohol or ethanol into a first sponge block, and then moves the first sponge block back and forth, so that the movable contact plate and the normally closed contact plate in the relay and the contacts on the normally open contact plate can be wiped and cleaned, thereby effectively cleaning and removing the dirt and mucus on the contact surface, thereby preventing the relay from having problems such as poor contact in subsequent use, which affects the operation of the relay.

Owner:HUNAN SHENGMENG CIVIL ENG CO LTD
Automatic rain protection for touch screens
ActiveCN108255337BEasy to useExtended service lifeInput/output processes for data processingElectric machineryTouchscreen
The invention relates to a rainproof device, and discloses an automatic rainproof device for a touch screen. The automatic rainproof device comprises a touch screen carrier (1), and an installing panel (3) is arranged on the touch screen carrier (1); the automatic rainproof device also comprises a motor (4) and a transverse rotating shaft (5) connected on a motor shaft, the touch screen (2) is installed in the middle of the installing panel (3), stretchable rods (6) are arranged at the back edge of the installing panel (3), the top ends of the stretchable rods (6) are connected on the transverse rotating shaft (5), a transparent plastic film (7) is arranged on the side wall of the transverse rotating shaft (5), and vertical supporting rods (8) perpendicular to the transverse rotating shaft(5) are arranged at the back portion of the transparent plastic film (7). According to the automatic rainproof device for the touch screen, the plastic film is arranged on the touch screen, the rainproof effect is achieved on the premise that the touch screen is not influenced by the plastic film, the touch screen can also be effectively used even if it is rainy, the service life of the touch screen is prolonged, and the use sensitivity of the touch screen is improved.


Owner:杭州锐同科技有限公司
Vehicle mechanical steering wheel assembly
InactiveCN108275196AGood elastic connectionReduce wearHand wheelsSteering columnsSteering columnSteering wheel
The invention discloses a vehicle mechanical steering wheel assembly. The assembly comprises a steering wheel, a steering column, a connecting stud, a steering shaft, a pin and a shock-absorbing rubber sleeve, the steering column is arranged below the steering wheel, the connecting stud is arranged in the steering column, the steering shaft is arranged behind the steering column, the steering shaft is rotatably connected with the steering stud through the steering column, the steering shaft is arranged behind the pin, the shock-absorbing rubber sleeve is arranged behind the pin, and the shock-absorbing rubber sleeve is in contact connection with the steering shaft through the pin. By means of the assembly, an interior buffering spring is conveniently matched by arranging the pin with the shock-absorbing rubber sleeve to enhance the buffering capability with a shaft rod, the protective effect on the buffering spring is enhanced by arranging a lower steering shaft with a plastic sleeve to prevent the invasion of oil, and the assembly is simple in structure and easy to implement.


Owner:海宁汉钟机械设备有限公司
Anti-collision sensing type door and window opening and closing device
InactiveCN104908676AReduce damage rateFlexible installationElectric/fluid circuitWindow openingContact type
The invention discloses an anti-collision sensing type door and window opening and closing device, and relates to the technical field of vehicle structures. The device is sensitive, flexible to mount, not prone to being damaged, reliable and durable in use. The device is a non-contact type door and window opening and closing device with both corrosion preventing of external vehicle parts and sealing of internal vehicle parts considered. The device comprises a sensing base nut (1), a spring (2), a steel ball (3), a door and window sensing base (4), a door and window opening and closing sealing sleeve, a door and window opening and closing fixing fastener assembly and a door and window opening and closing sensor. All door and window opening / closing state signals of a vehicle are provided for a driver of the vehicle. The device is simple in structure, the device is improved based on an original vehicle door and window opening and closing device, an elastic contact mode is adopted, the service life of the door and window opening and closing device is greatly prolonged, the sensitivity of the door and window opening and closing device is greatly improved, and part of daily using and maintaining cost is saved for users of the vehicle.


Owner:BEIJING NORTH VEHICLE GROUP CORP
A multi-axis CNC mechanical gripper based on parallel mechanism
ActiveCN113524145BLarge operating rangeImprove usage sensitivityProgramme-controlled manipulatorGripping headsElectric machineryPhysics

Owner:CHONGQING YUWEI PRECISION IND CO LTD
Processing technology of planar thick copper PCB
PendingCN111328205ASmooth rotationImprove usage sensitivityConductive material mechanical removalMachining processMaterials science
The invention discloses a processing technology of a planar thick copper PCB. The technology comprises: S2, enabling an upper surface circuit and a lower surface circuit of a semi-finished PCB to be covered by resin in prepregs, and enabling the circuits to be filled and leveled up by the resin in the prepregs; S3, grinding off redundant resin on the surface circuit by using a ceramic grinding brush on grinding equipment so as to ensure that the conductive pattern of the surface circuit is just exposed; S4, the grinding frequency is controlled within 5-6 times, and at the moment, the exposed circuits and the resin filled between the circuits are located on the same plane; S6, performing surface treatment on the pattern of the PCB for the multi-turn precision wire-wound potentiometer; and checking the PCB after surface treatment, thereby finally obtaining the finished product of the PCB for the multi-turn precision wire-wound potentiometer. The invention has the beneficial effects thatthe pointer and the base material can be leveled into the same plane, the pointer can be ensured to smoothly rotate after being assembled by a user, and the contact sensitivity of a product is improved.
Owner:四川英创力电子科技股份有限公司
Indoor environment detection alarm device
ActiveCN222188416UKeep surfaces cleanImprove usage sensitivityMeasurement apparatus housingsAlarmsDrive shaftDrive motor
The utility model discloses indoor environment detection alarm equipment, which relates to the field of environment detection alarm equipment and comprises a base, a detection box mounted at the upper end of the base, a transverse rotating shaft connected to the bottom end of the detection box, a support frame connected to the upper end of the base, and a top plate connected to the top end of the support frame. The upper end of the top plate is connected with a driving motor, the output end of the driving motor is connected with a transmission shaft, the lower end of the top plate is provided with fan blades, one end of the transmission shaft is connected with the fan blades, and the lower portions of the fan blades are matched with the position of the detection box. The upper end of the cover plate is connected with an alarm lamp. The upper end of the top plate is connected with the driving motor, the output end of the driving motor is connected with the fan blades at the lower end of the top plate, dust on the surfaces of the alarm lamp and the buzzer is blown away when necessary, the flashing brightness of the alarm lamp is kept, and the warning effect is improved.

Owner:SICHUAN RUICHENG ANHUI TECHNOLOGY CO LTD