
Patents
Literature
67results about How to "Simplify the tuning process" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Tri-axial platform servo motor control method based on combination of BP neural network and active disturbance rejection controller
ActiveCN108646572ASimple control structureImprove control effectAdaptive controlElectric machineryComputer module
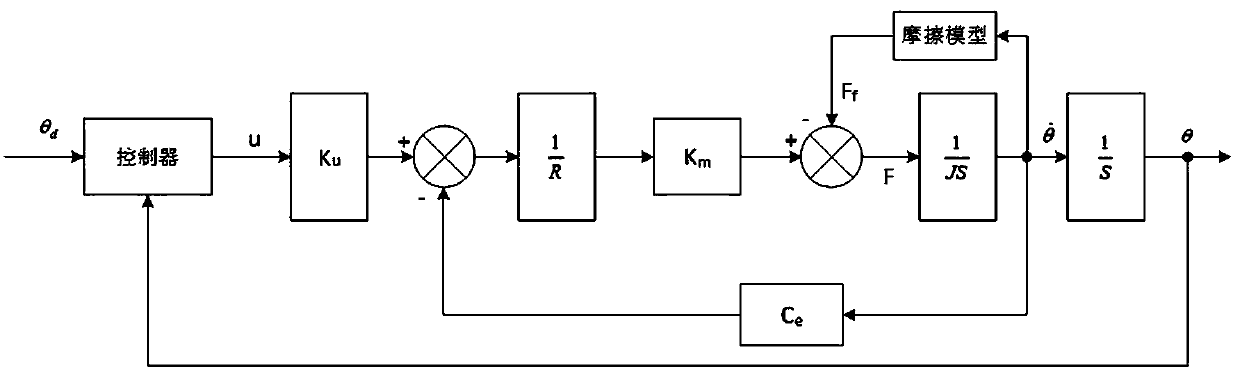
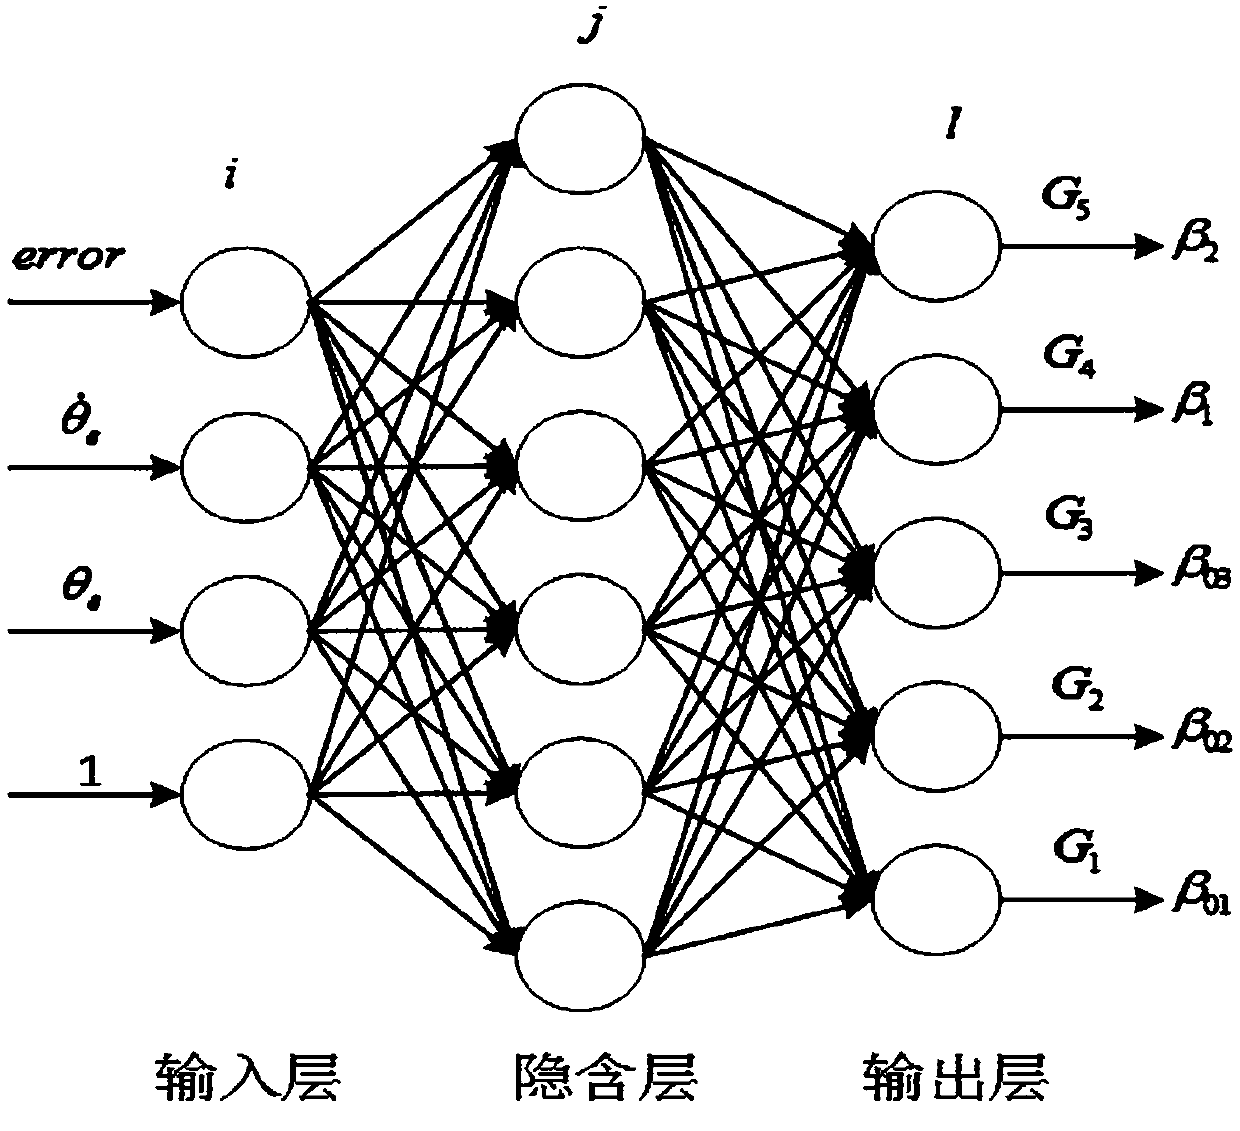
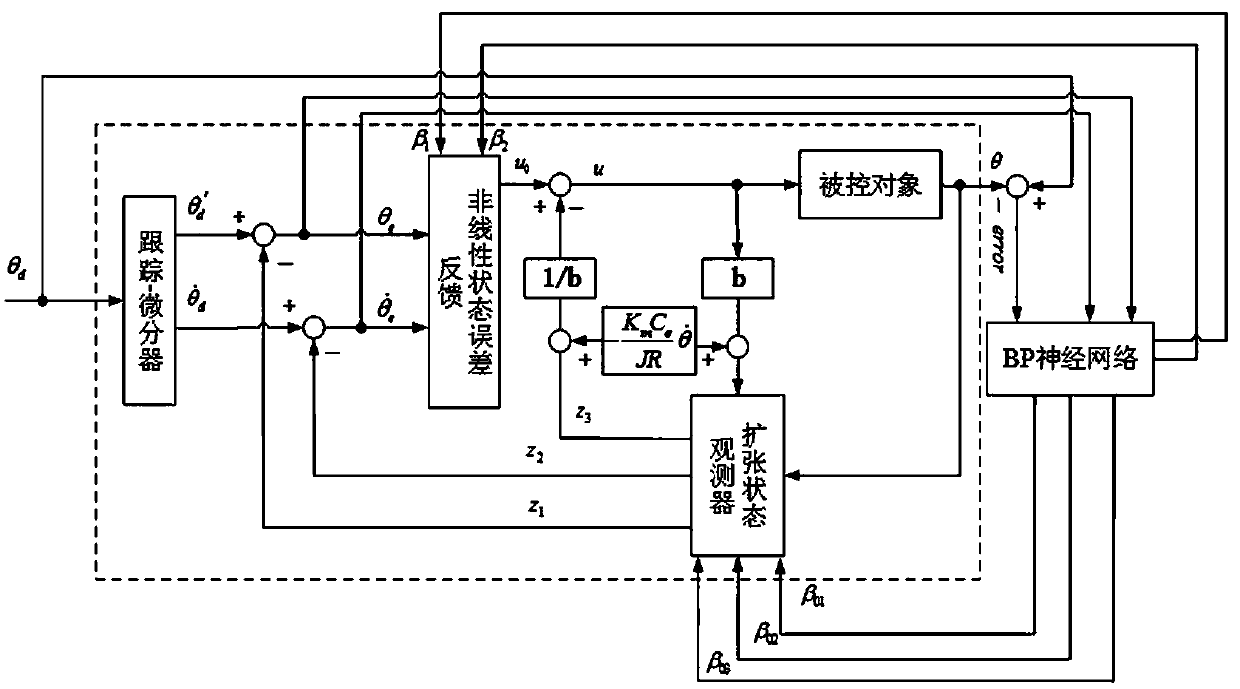
The invention discloses a tri-axial platform servo motor control method based on the combination of a BP neural network and an active disturbance rejection controller. The tri-axial platform servo motor control method includes the following steps that 1, the kinetic equation of a tri-axial platform arbitrary-frame servo system containing a friction model is built; 2,according to the kinetic equation in the formula (I),the active disturbance rejection controller is designed; 3,a BP neural network parameter on-line setting module is designed and combined with the active disturbance rejection controller, and active disturbance rejection controller on-line parameter setting is achieved. By the adoption of the tri-axial platform servo motor control method based on the combination of the BP neural network and the active disturbance rejection controller, a flat top phenomenon and a dead zone phenomenon of a servo system can be basically eliminated, wherein the flat top phenomenon occurs during position signal tracking, and the dead zone phenomenon occurs during speed signal tracking; therefore, the position tracking precision and the speed tracking precision of the servo system can be improved.
Owner:GUANGXI NORMAL UNIV
Automatic flight control simulation system for general flight simulator
InactiveCN107783429AEasy to callSimplify the tuning processGeometric CADSimulator controlComputer moduleFlight simulator
The invention discloses an automatic flight control simulation system for a general flight simulator. According to the technical scheme, the system comprises a flight guide module, an automatic pilotmodule, an auto-throttle module, an automatic landing module, an automatic navigation module, an automatic trim module and a module control logic / data configuration file module. The module control logic / data configuration file module comprises a control logic module and a data configuration module. The control logic module is used for judging whether each module meets an access condition or not before the access of the module, judging whether the above module is in contradiction with a currently operated module or not during the access of the module, and judging whether other modules need to be accessed or not before the exit of the currently operated module. The data configuration module is used for describing the control rates of the flight guide module, the automatic pilot module, the auto-throttle module, the automatic landing module, the automatic navigation module and the automatic trim module. In this way, the general design of the automatic flight control simulation system canbe realized.


Owner:北京蓝天航空科技股份有限公司
Substation area backup protection method based on combination of direction comparison and current differential
ActiveCN103779841ALower performance requirementsFast actionEmergency protective circuit arrangementsData synchronizationTime delays
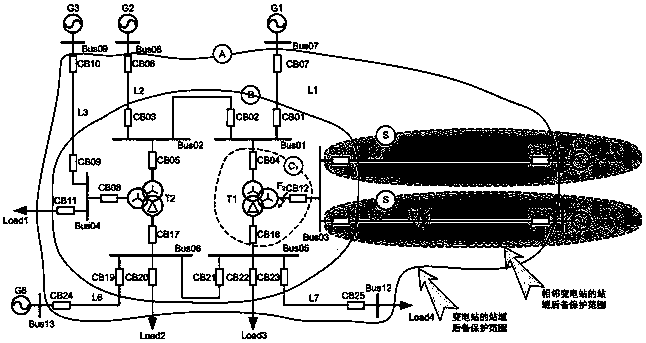
The invention discloses a substation area backup protection method based on combination of direction comparison and current differential. In the method, zoning processing is performed on a backup protection range so that an application status that backup protection relies on fault electric quantity and time-limit ladder cooperation to realize selectivity is changed and the movement speed of the backup protection is improved; a current differential principle and a direction comparison principle are used comprehensively for fault positioning so that not only is absolute selectivity of the differential principle is used, but advantages that direction elements have lower demands on sampling value data synchronization are used, and at the same time, performance demands on inter-station data channels are reduced; after system faults are detected, time delay for Nms is performed to wait for a main protection motion, wherein N belongs to a range of [250, 350]; if the main protection refuses to move, a backup tripping command is sent out; and if a circuit breaker is out of order, an out-of-order tripping command is sent to an expansion tripping area. Compared with ladder time delay of at least 500ms for one differential adopted by traditional backup protection, the method is faster in motion rapid.
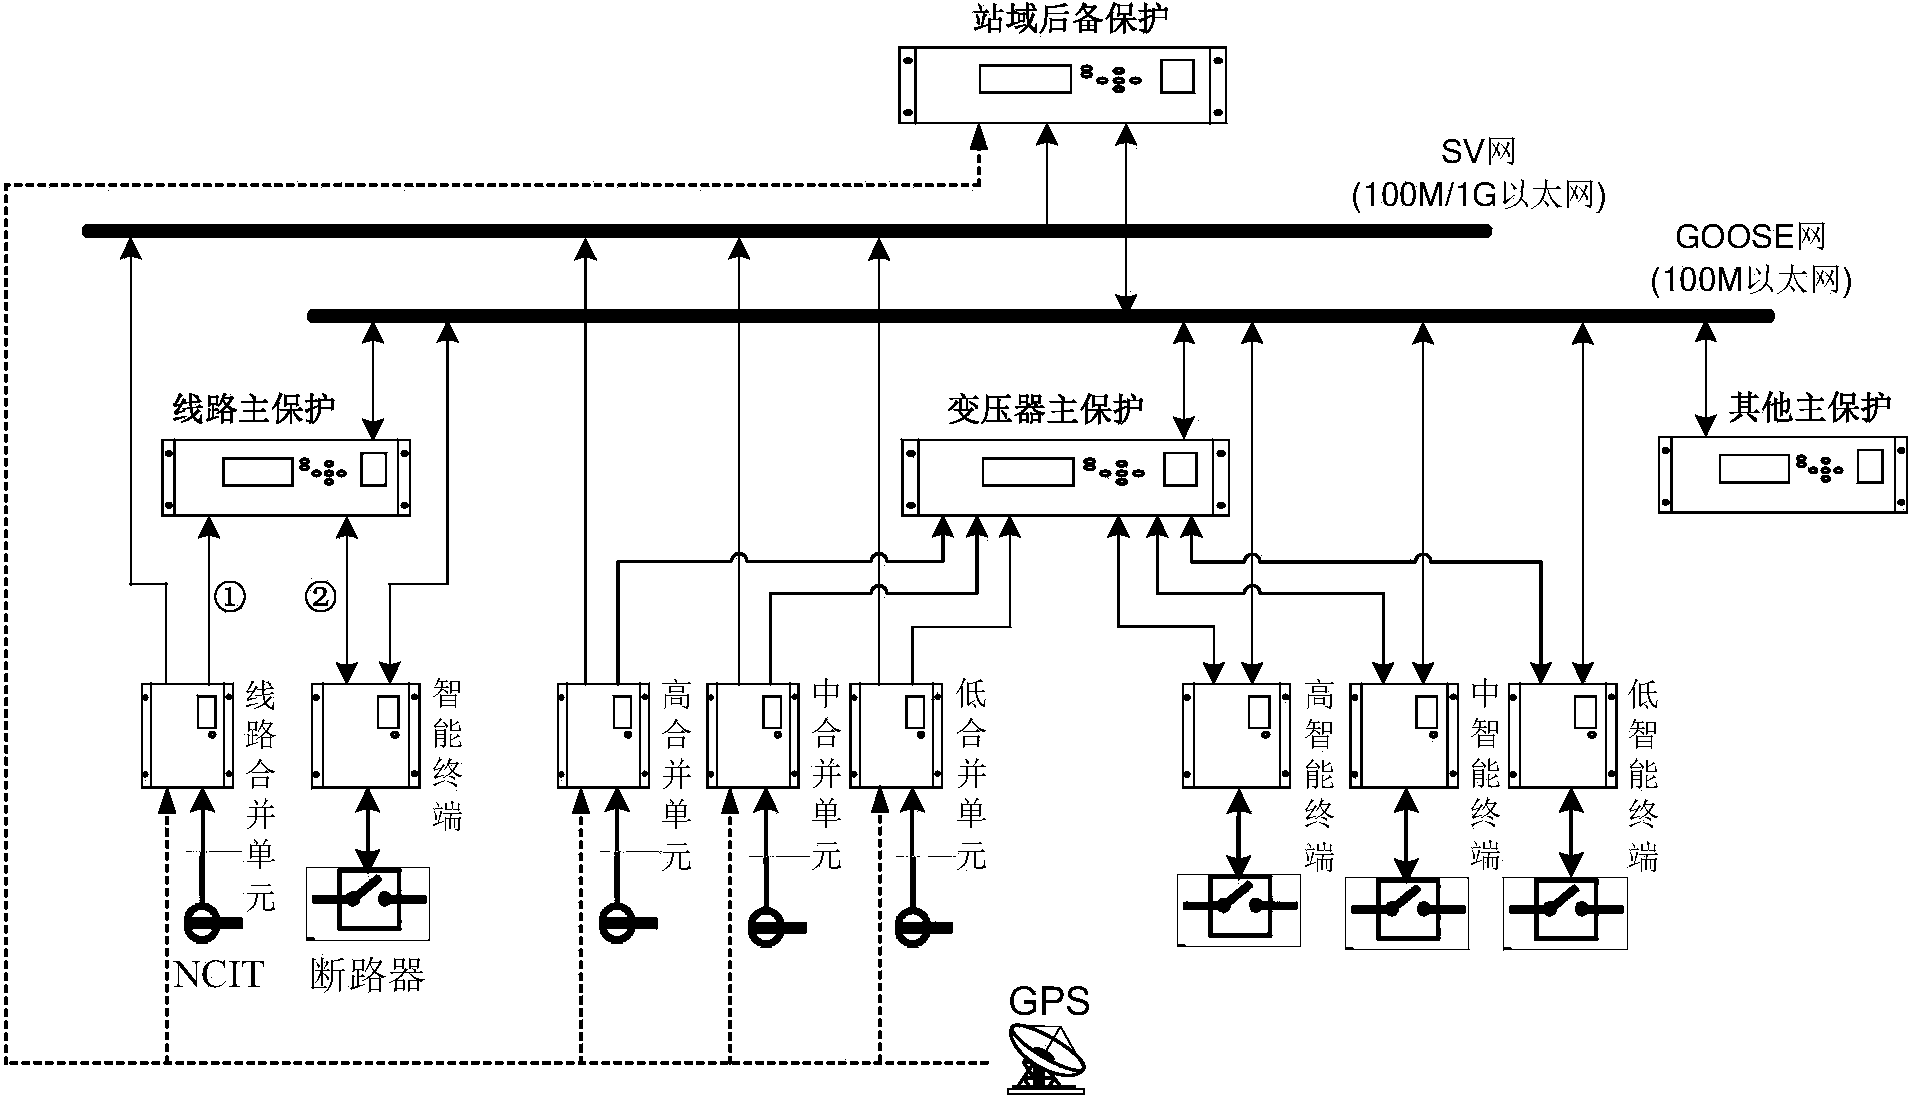
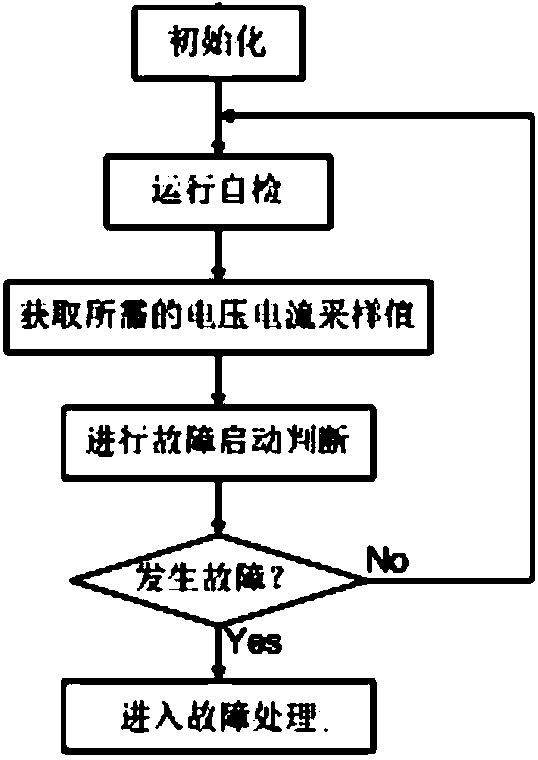
Owner:STATE GRID CORP OF CHINA +1
Permanent magnet synchronous motor low-speed domain rotor position identification method
ActiveCN110429886AImprove stabilityFast convergenceElectronic commutation motor controlElectric motor controlHysteresisIntegrator
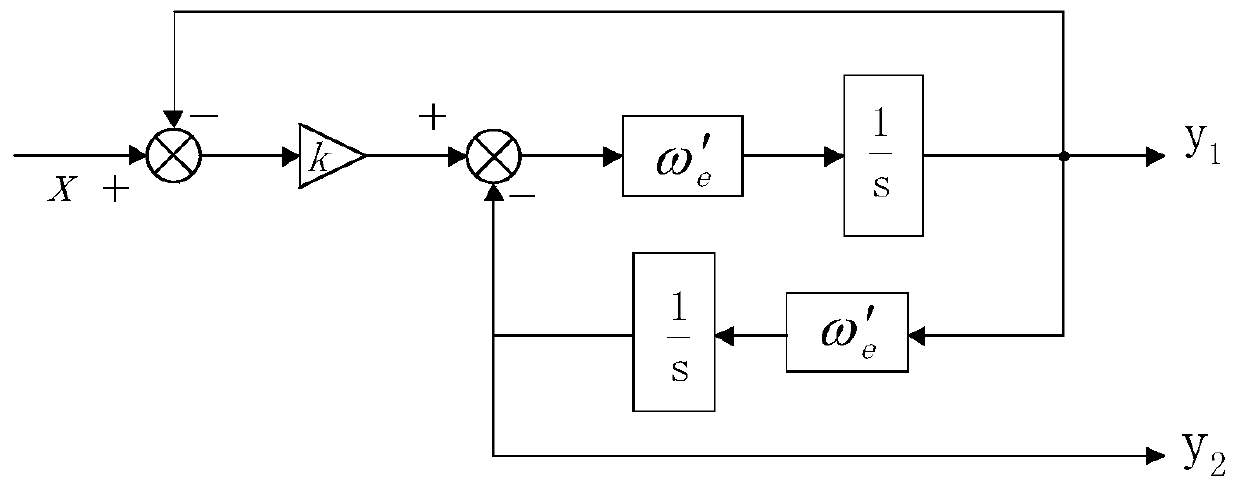
The invention discloses a permanent magnet synchronous motor low-speed domain rotor position identification method, so as to solve the problems that the traditional pulse signal injection method usesmultiple filters, the hysteresis effects are superimposed, the dynamic performance of the system is reduced, and the position estimation error is increased. A new low-speed position sensorless controlstrategy is proposed. In particular, on the basis of injection of a high-frequency pulse square wave voltage signal to a two-phase stationary coordinate system, through a generalized second-order integrator (SOGI), current in a beta axis is subjected to signal separation and amplitude demodulation, two paths of orthogonal signals including rotor position information are obtained, and through heterodyne and a rotor position observer, the rotor position information is extracted, and no filter is used during the whole signal demodulation process. The dynamic performance of the control system andthe accuracy of the rotor position estimation are effectively improved.
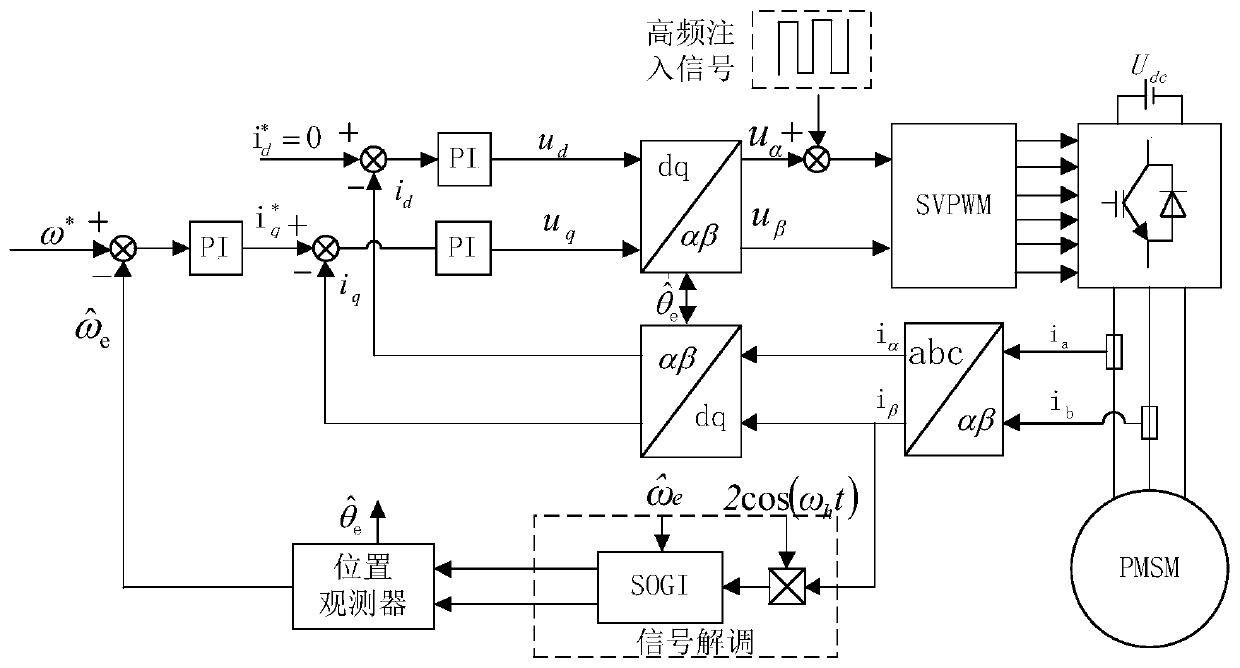
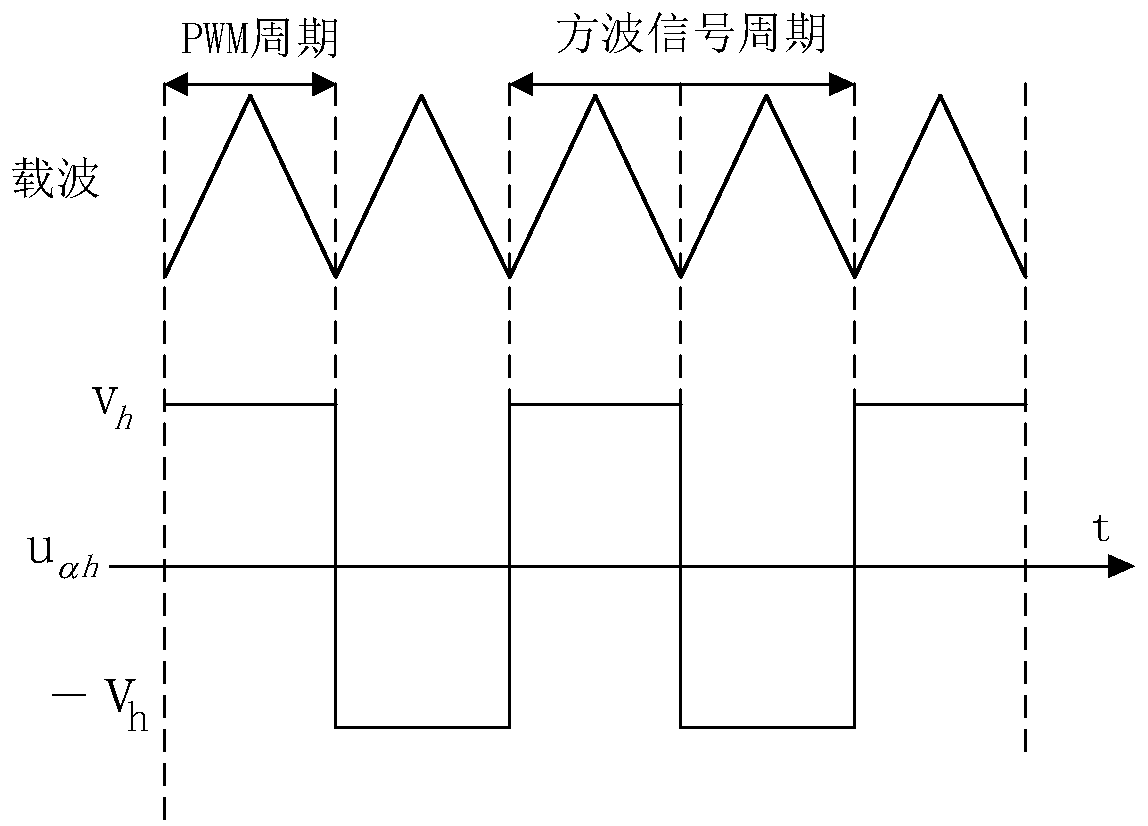
Owner:JIANGSU UNIV
Harmonic controller for energy-storing system of wind-power plant and parameter-setting method thereof
InactiveCN103078322AKeep it simple and effectiveFully exert the inhibitory functionAc network voltage adjustmentHarmonic reduction arrangementClosed loopEngineering
The invention discloses a harmonic controller for an energy-storing system of a wind-power plant, which comprises the energy-storing system, a DC (Direct current) / DC converter, an electric network, a bidirectional current transformer, an SPWM (Sinusoidal Pulse Width Modulation) converter and a double closed-loop control system, wherein the double closed-loop control system comprises an outer-ring voltage P1 controller, an inner-ring current PR controller, a first comparator and a second comparator; and the invention also designs a parameter-setting method of the harmonic controller for the energy-storing system of the wind-power plant. According to the invention, the energy-storing system can be inhibited from injecting harmonic waves into the electric network on the basis of controlling the voltage and the current of the energy-storing system to be stable.


Owner:HOHAI UNIV
Substation area protection based integrated failure protection method for substations
ActiveCN103384058AAccurate identificationIntegrated failure protection realizationEmergency protective circuit arrangementsPower substationReliability engineering
The invention discloses a substation area protection based integrated failure protection method for substations. On the basis of substation area protection devices, an automatic topological structure identification and minimum area difference stream detection method is used for achieving integrated failure protection of the whole substations, failure protection wiring and setting can be simplified, failed breakers can be identified quickly and accurately, failures can be isolated in minimum power outage ranges, failure protection actuation time is shortened, reliability of failure protection is improved, and the method is applicable to the substations with voltage classes between 110kV and 1000kV and has the good application prospect.


Owner:NARI TECH CO LTD +1
Respiratory system disease patient number prediction method based on lag analysis and LSTM
InactiveCN110706823AImprove forecast accuracyGuaranteed reasonablenessEpidemiological alert systemsCharacter and pattern recognitionPhysical medicine and rehabilitationPredictive methods
The invention relates to a respiratory system disease patient number prediction method based on lag analysis and LSTM. The influence of atmospheric pollutants and meteorological conditions on human respiratory system diseases is combined, a deep learning technology is adopted to predict the target disease patient number, and the prediction precision of the respiratory system disease patient numbercan be effectively improved. The hysteresis effect of atmospheric pollutants on respiratory system diseases is brought into analysis, a deep learning time step length setting method based on hysteresis analysis is provided, and the adjustment and optimization process of LSTM network parameters can be effectively simplified on the premise of ensuring the rationality of the model.


Owner:GUANGZHOU INST OF GEOGRAPHY GUANGDONG ACAD OF SCI
Coal-mine gas movement detection data processing method of mine Internet of Things
ActiveCN103604914AImprove reliabilitySimplify the tuning problemMining devicesFuel testingData pointData processing
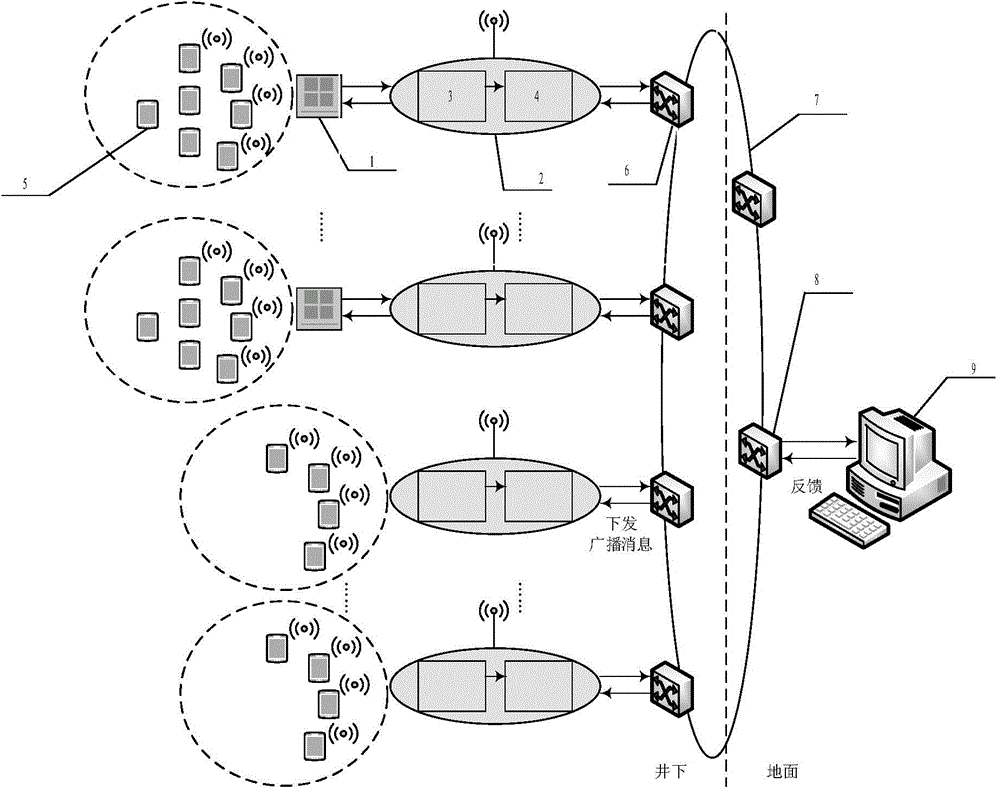
The invention discloses a coal-mine gas movement detection data processing method of mine Internet of Things, relating to the technical field of coal-mine gas movement detection data processing. The coal-mine gas movement detection data processing method comprises the following steps: installing a wireless access point composed of a sensor preprocessing unit and a sensor judging unit near each fixed gas detector; after simply processing and judging data detected by the fixed gas detectors and data detected by mobile gas detectors around the wireless access points by the wireless access points, uploading the data to a ground workstation through an underground switch, a coal mine Internet of Things transmission platform and a ground switch, grouping the gas detected by the mobile gas detectors and the data detected by the fixed gas detectors into two kinds of data of multi-dimensional gas data points and gas detection data pairs by the ground workstation, carrying out global judgment by respectively adopting a clustering-based adaptive weighting data fusion algorithm and a single-sensor and multi-measurement period credibility fusion algorithm, and issuing a global judgment result to each wireless access point in a broadcasting form. The reliability of the detected data is improved.
Owner:CHINA UNIV OF MINING & TECH
Digitized liquid level measuring method using laser conduction
InactiveCN1877267ASimple structureReduce usageMachines/enginesLevel indicatorsLevel measurementLaser light
Disclosed is a method for measuring laser conductive and digital quantizing liquid level. The method comprises setting laser diodes array along the axial of a cylindrical transparent connecting vessels, wherein the height of the laser diodes array is greater than the measuring range of the liquid level to be measured; setting a background on the opposite position of the cylindrical transparent connecting sampler to make the laser light beam emitted from the laser diodes array project on the background and form a vertical light striation, and defining the height of the liquid level according to the height of the light striation; setting photosensitive tubes array on the site of the light striation for receiving laser beam, wherein the height of the photosensitive tubes array corresponds to the laser diodes array and equals the measuring range of the liquid level to be tested, and the situation shown by the photosensitive tubes represents the real height of the liquid level.
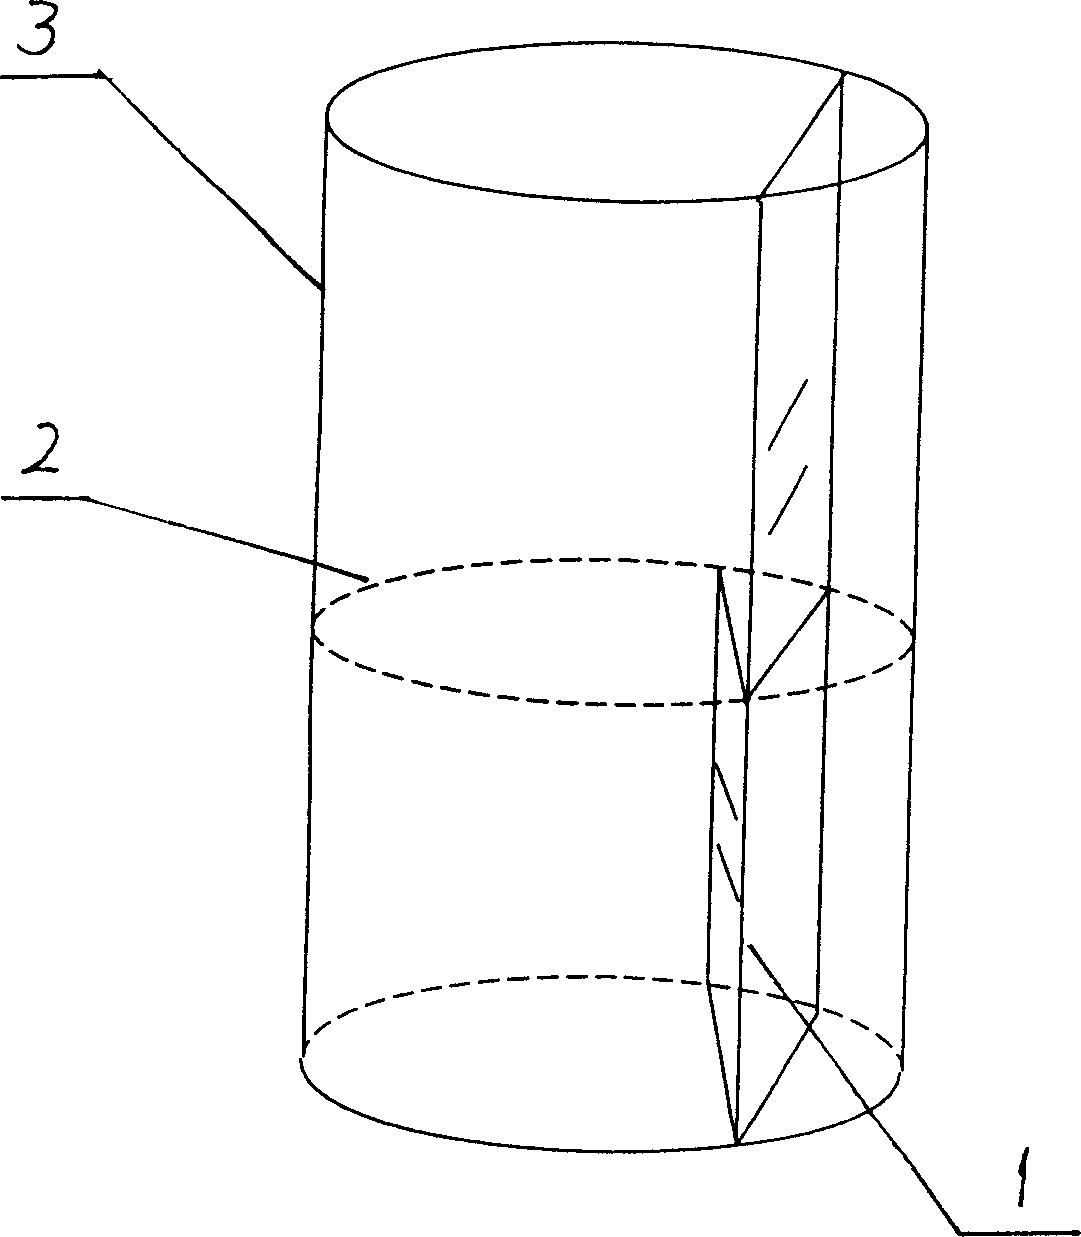
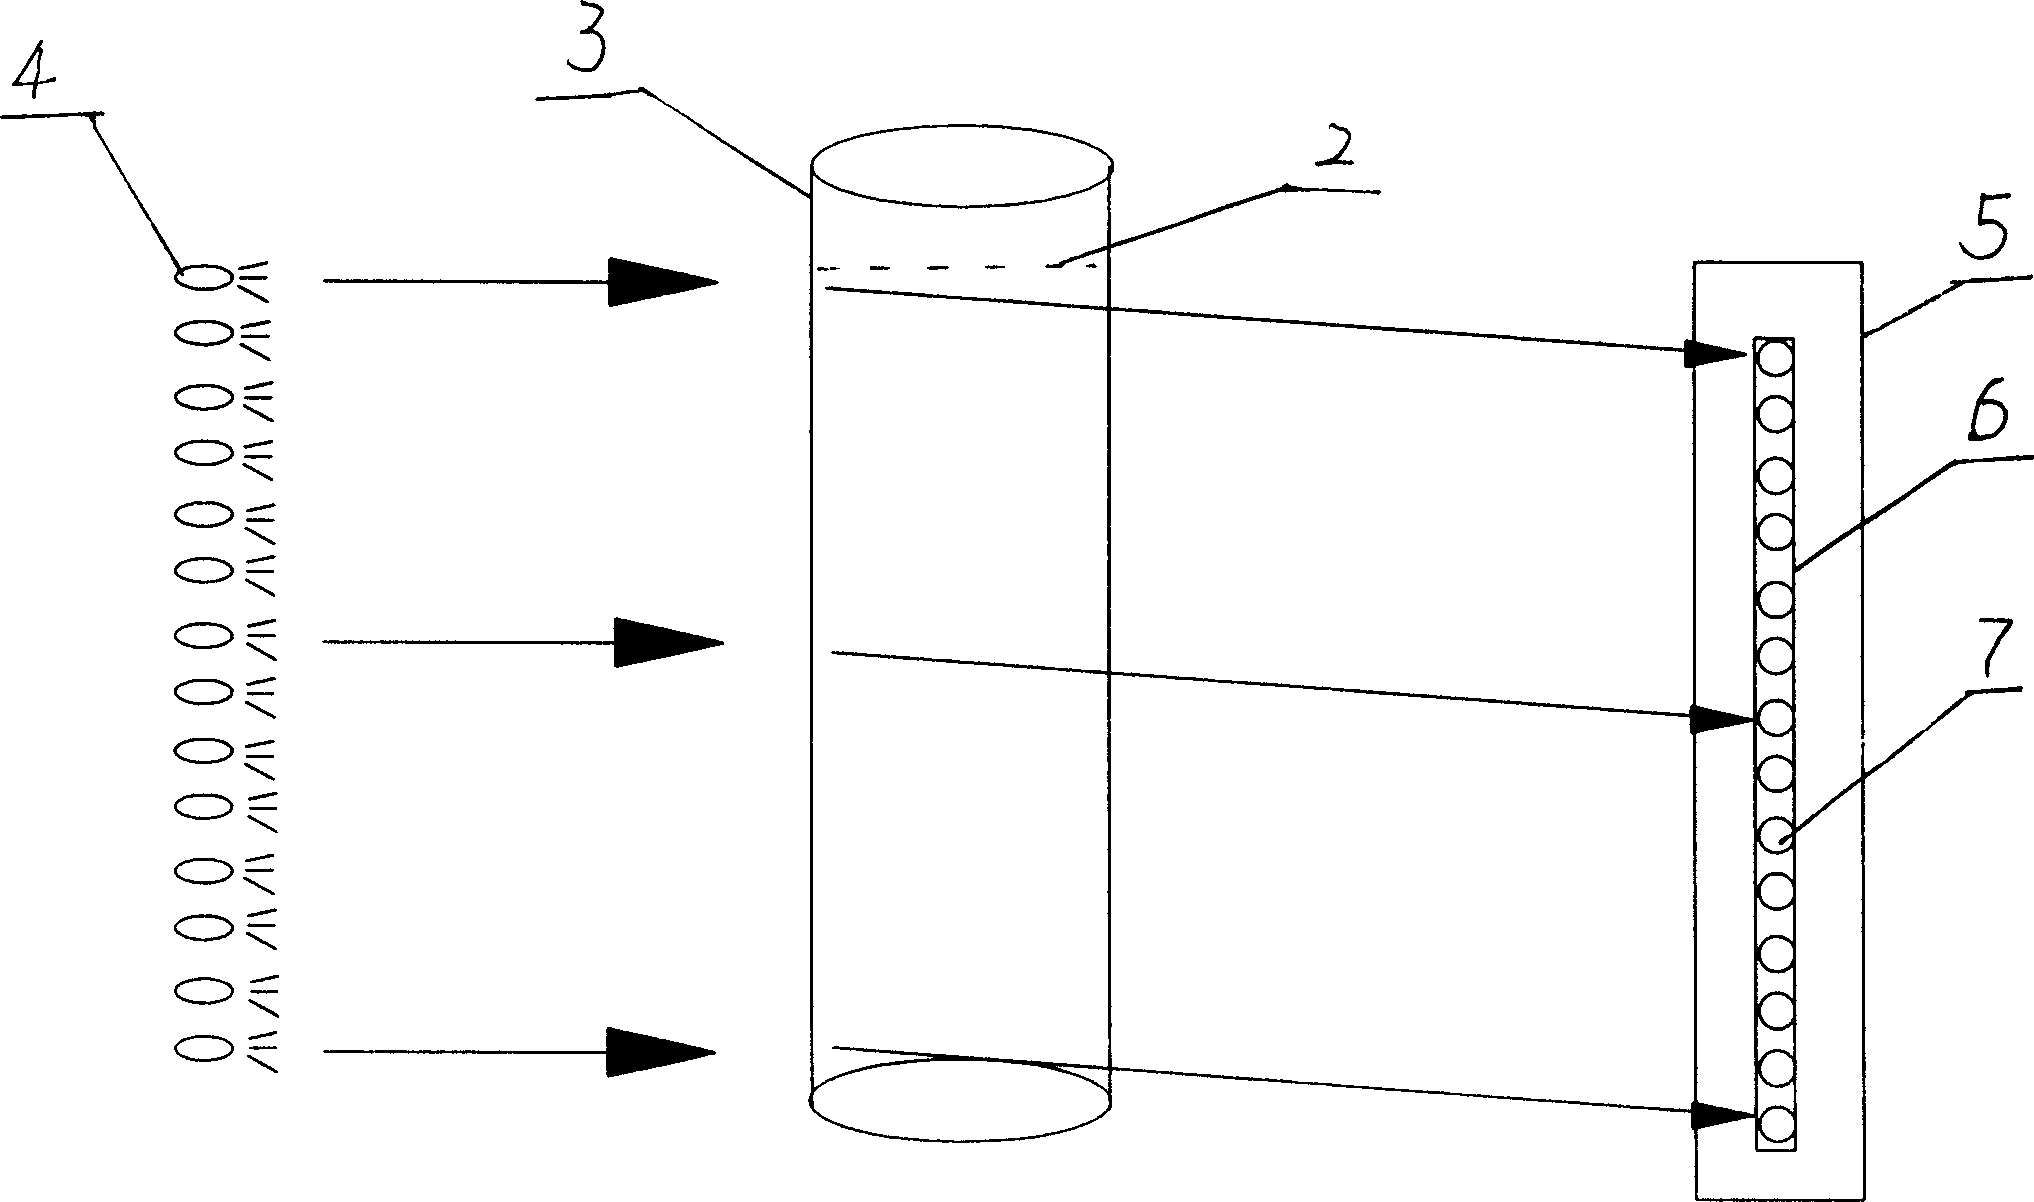
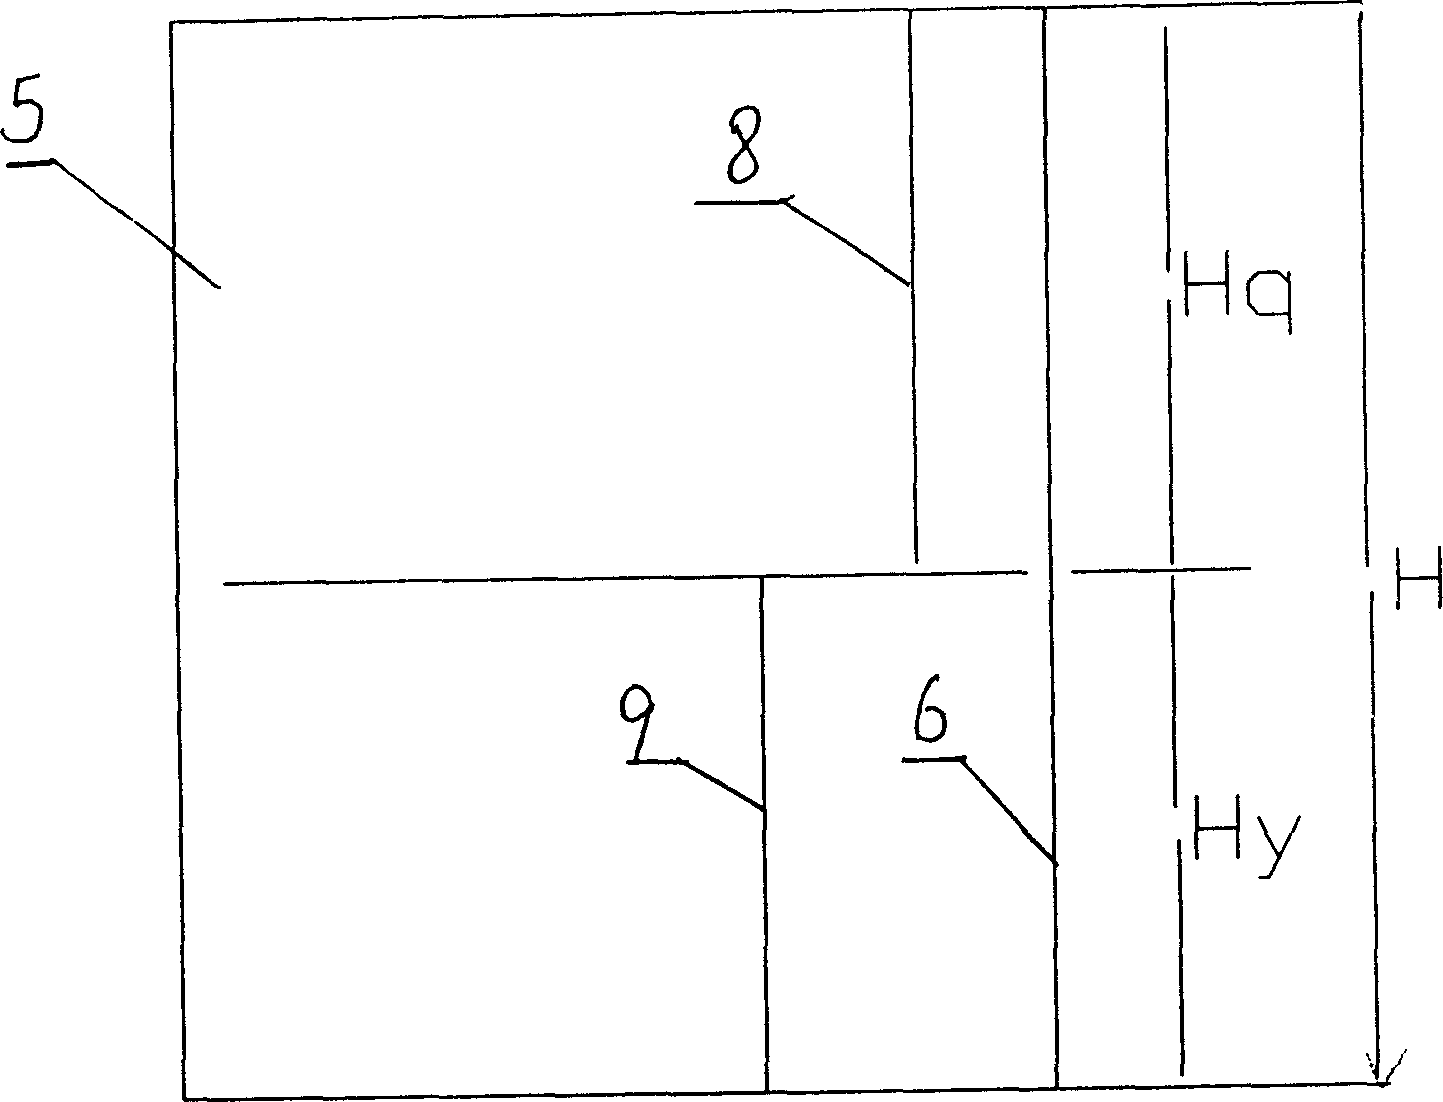
Owner:田逸
Air combat target threat assessment method based on standardized full-connection residual network
ActiveCN110472296ASolve the problem of inaccurate assessment resultsImprove information processing abilityCharacter and pattern recognitionNeural architecturesNetwork modelTargeted threat
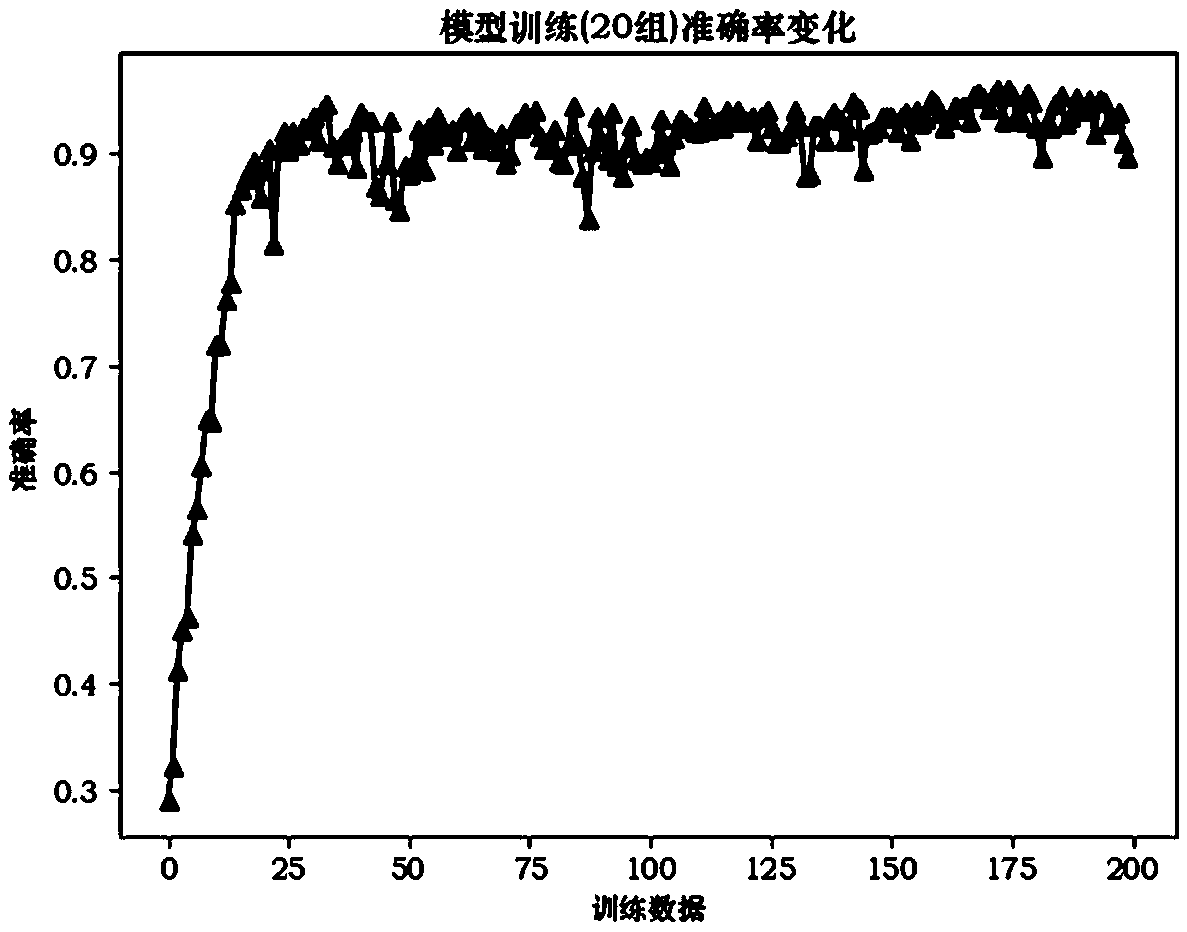
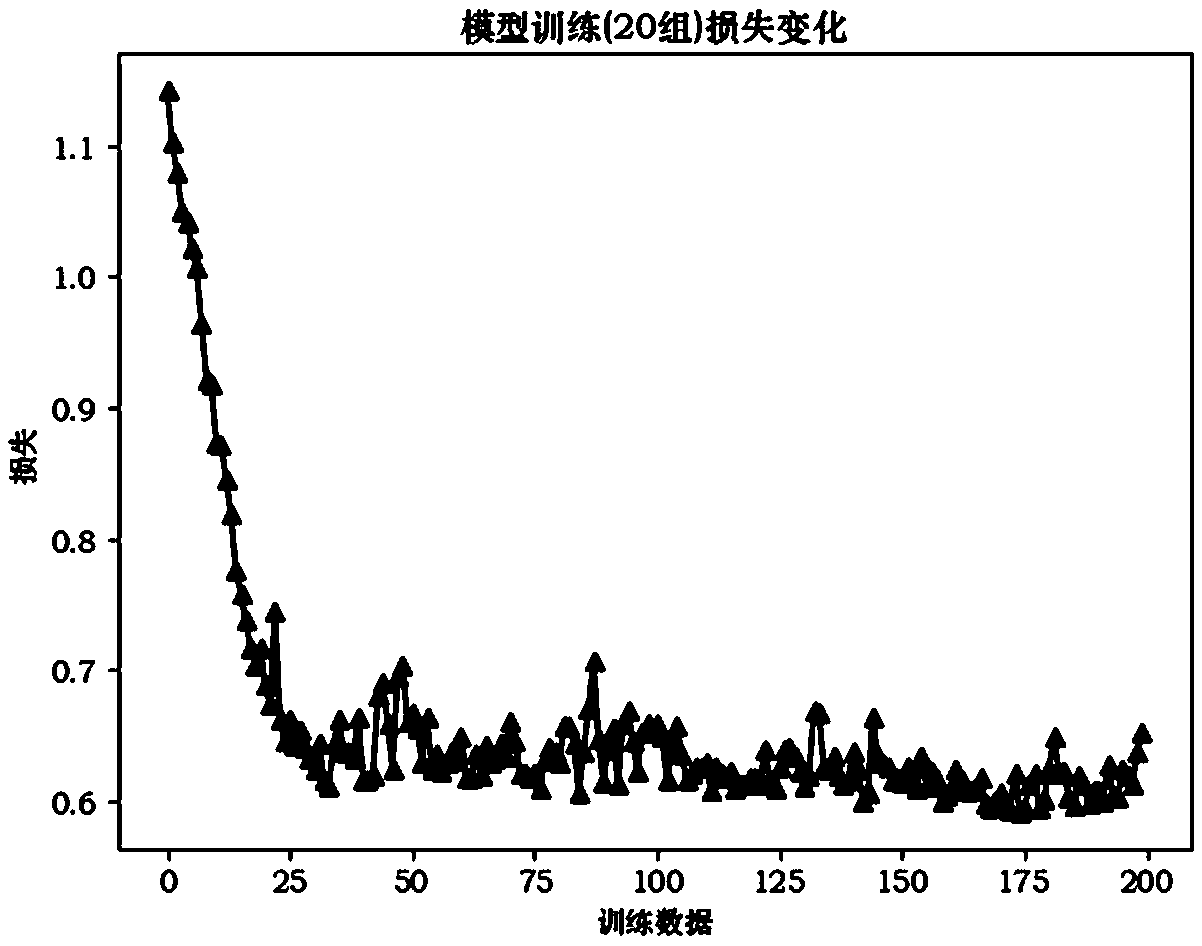
The invention discloses an air combat target threat assessment method based on a standardized full-connection residual network, and belongs to the field of battlefield situation assessment. Firstly, asimulation experiment is carried out to mark data; constructing a training set and a test set and storing the training set and the test set in a CSV file; secondly, constructing a standardized full-connection residual error network under a TensorFlow database, including constructing a graph for reading CSV file data, a residual error network layer and a standardized full-connection residual errornetwork graph, and finally creating a TensorFlow session, training a network model, testing, analyzing network performance and verifying the model. According to the method, the problem of inaccurateevaluation result caused by lack of self-learning reasoning capability for large sample data in other air combat target threat evaluation methods is solved, distribution of input data can be self-learned, rules hidden in the data can be mined, and the trained model can accurately evaluate the air combat target threat. The battlefield situation assessment method is mainly used for (but not limitedto) battlefield situation assessment.
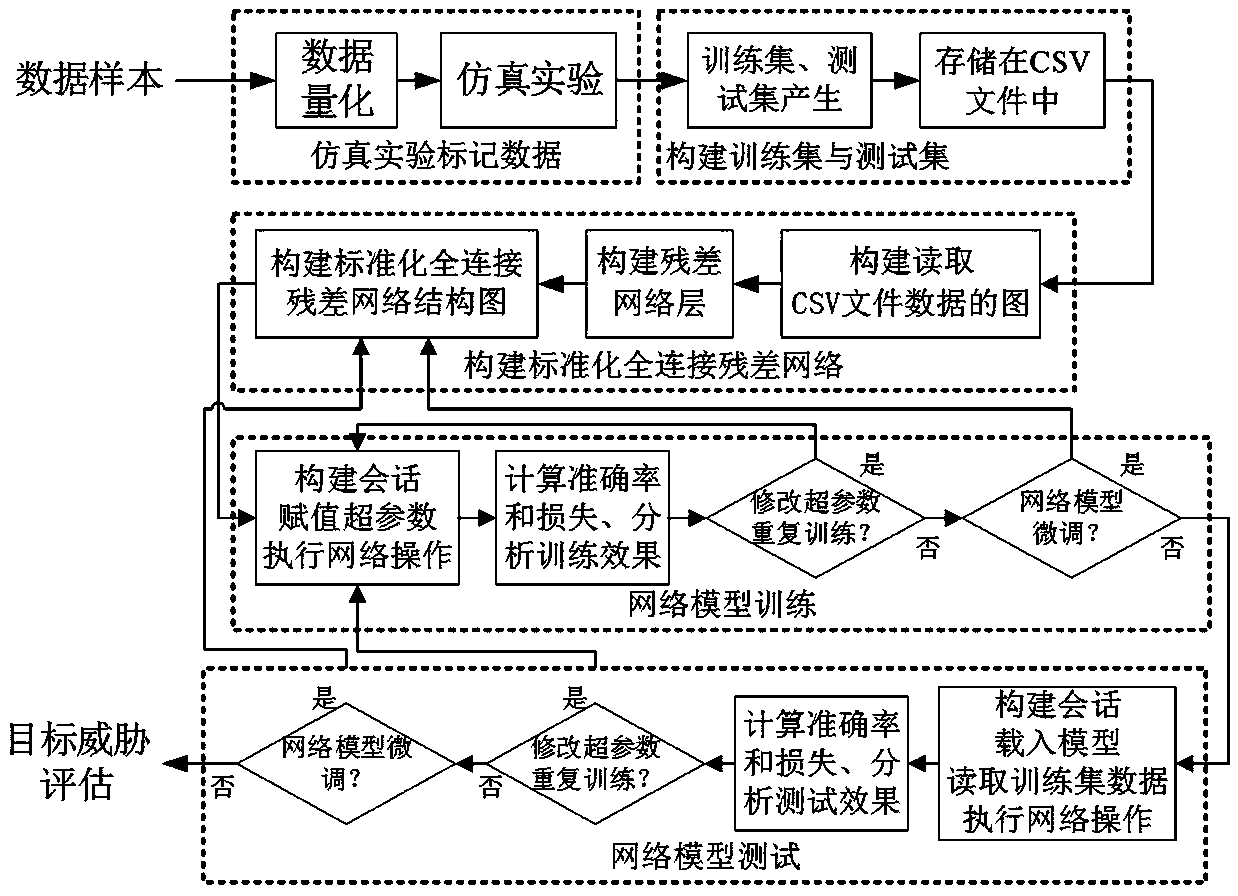
Owner:ZHONGBEI UNIV
RF power splitter for magnetic resonance system
InactiveCN102124603AReduced parts countReduce manufacturing costCoupling devicesResonanceRadio frequency signal
A radio frequency transmission system for a magnetic resonance system includes a radio frequency power amplifier (40) generating an input radio frequency signal that excites magnetic resonance in target nuclei and is designed for feeding an impedance Zo, a multi-channel radio frequency coil (18) having N radio frequency channels where N>1, and a power splitter (44) including (i) a parallel radio frequency connection point (50) at which the N channels of the radio frequency coil are connected in parallel to define an output impedance at the parallel radio frequency connection point, and (ii) an impedance matching circuit (54) connecting the radio frequency power amplifier with the radio frequency connection point and configured to provide impedance matching between the radio frequency power amplifier and the output impedance at the connection point.


Owner:KONINK PHILIPS ELECTRONICS NV
Parameter setting method for robust controller of direct current motor
ActiveCN104049541ASmall amount of calculationQuick set upSimulator controlDifferential coefficientAutomatic control
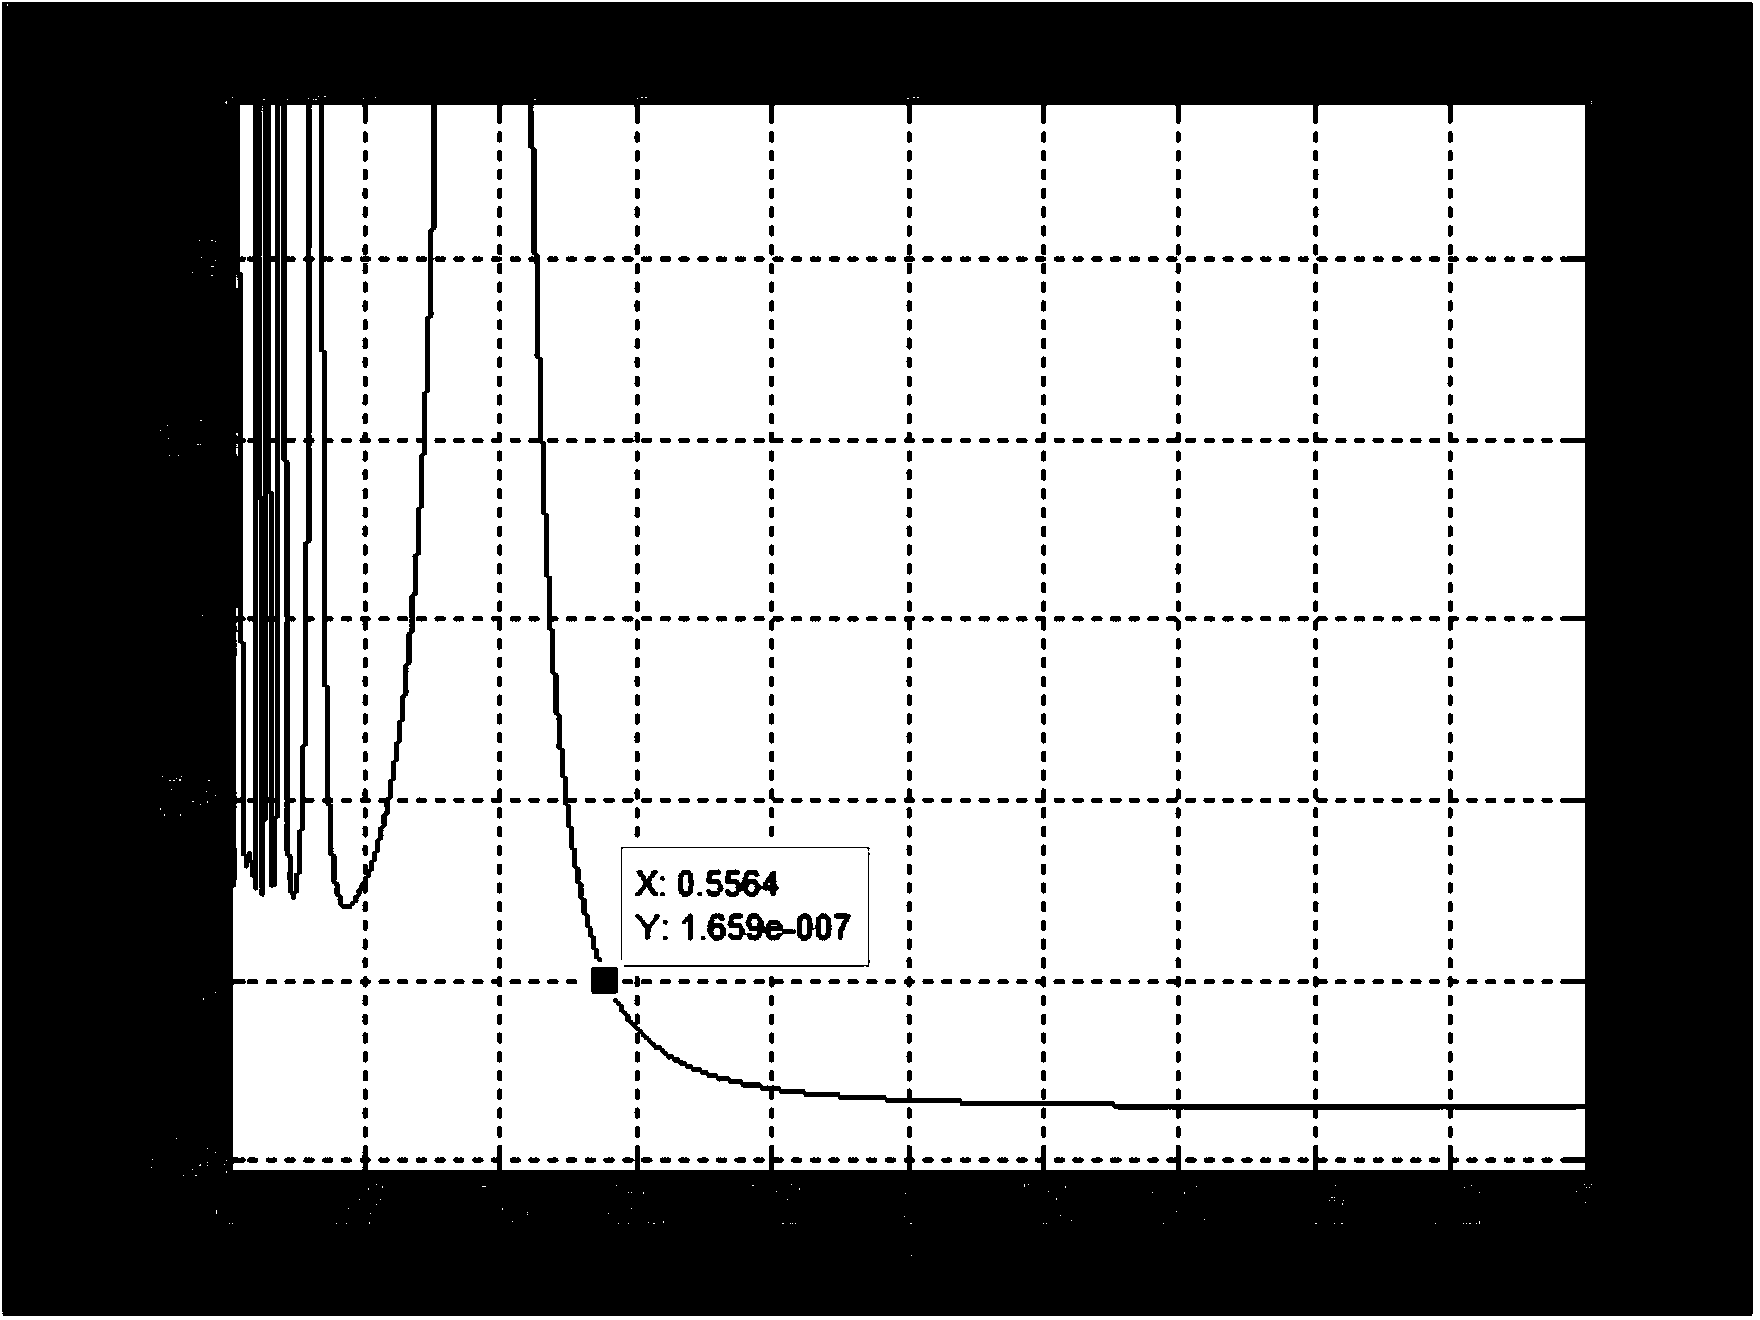
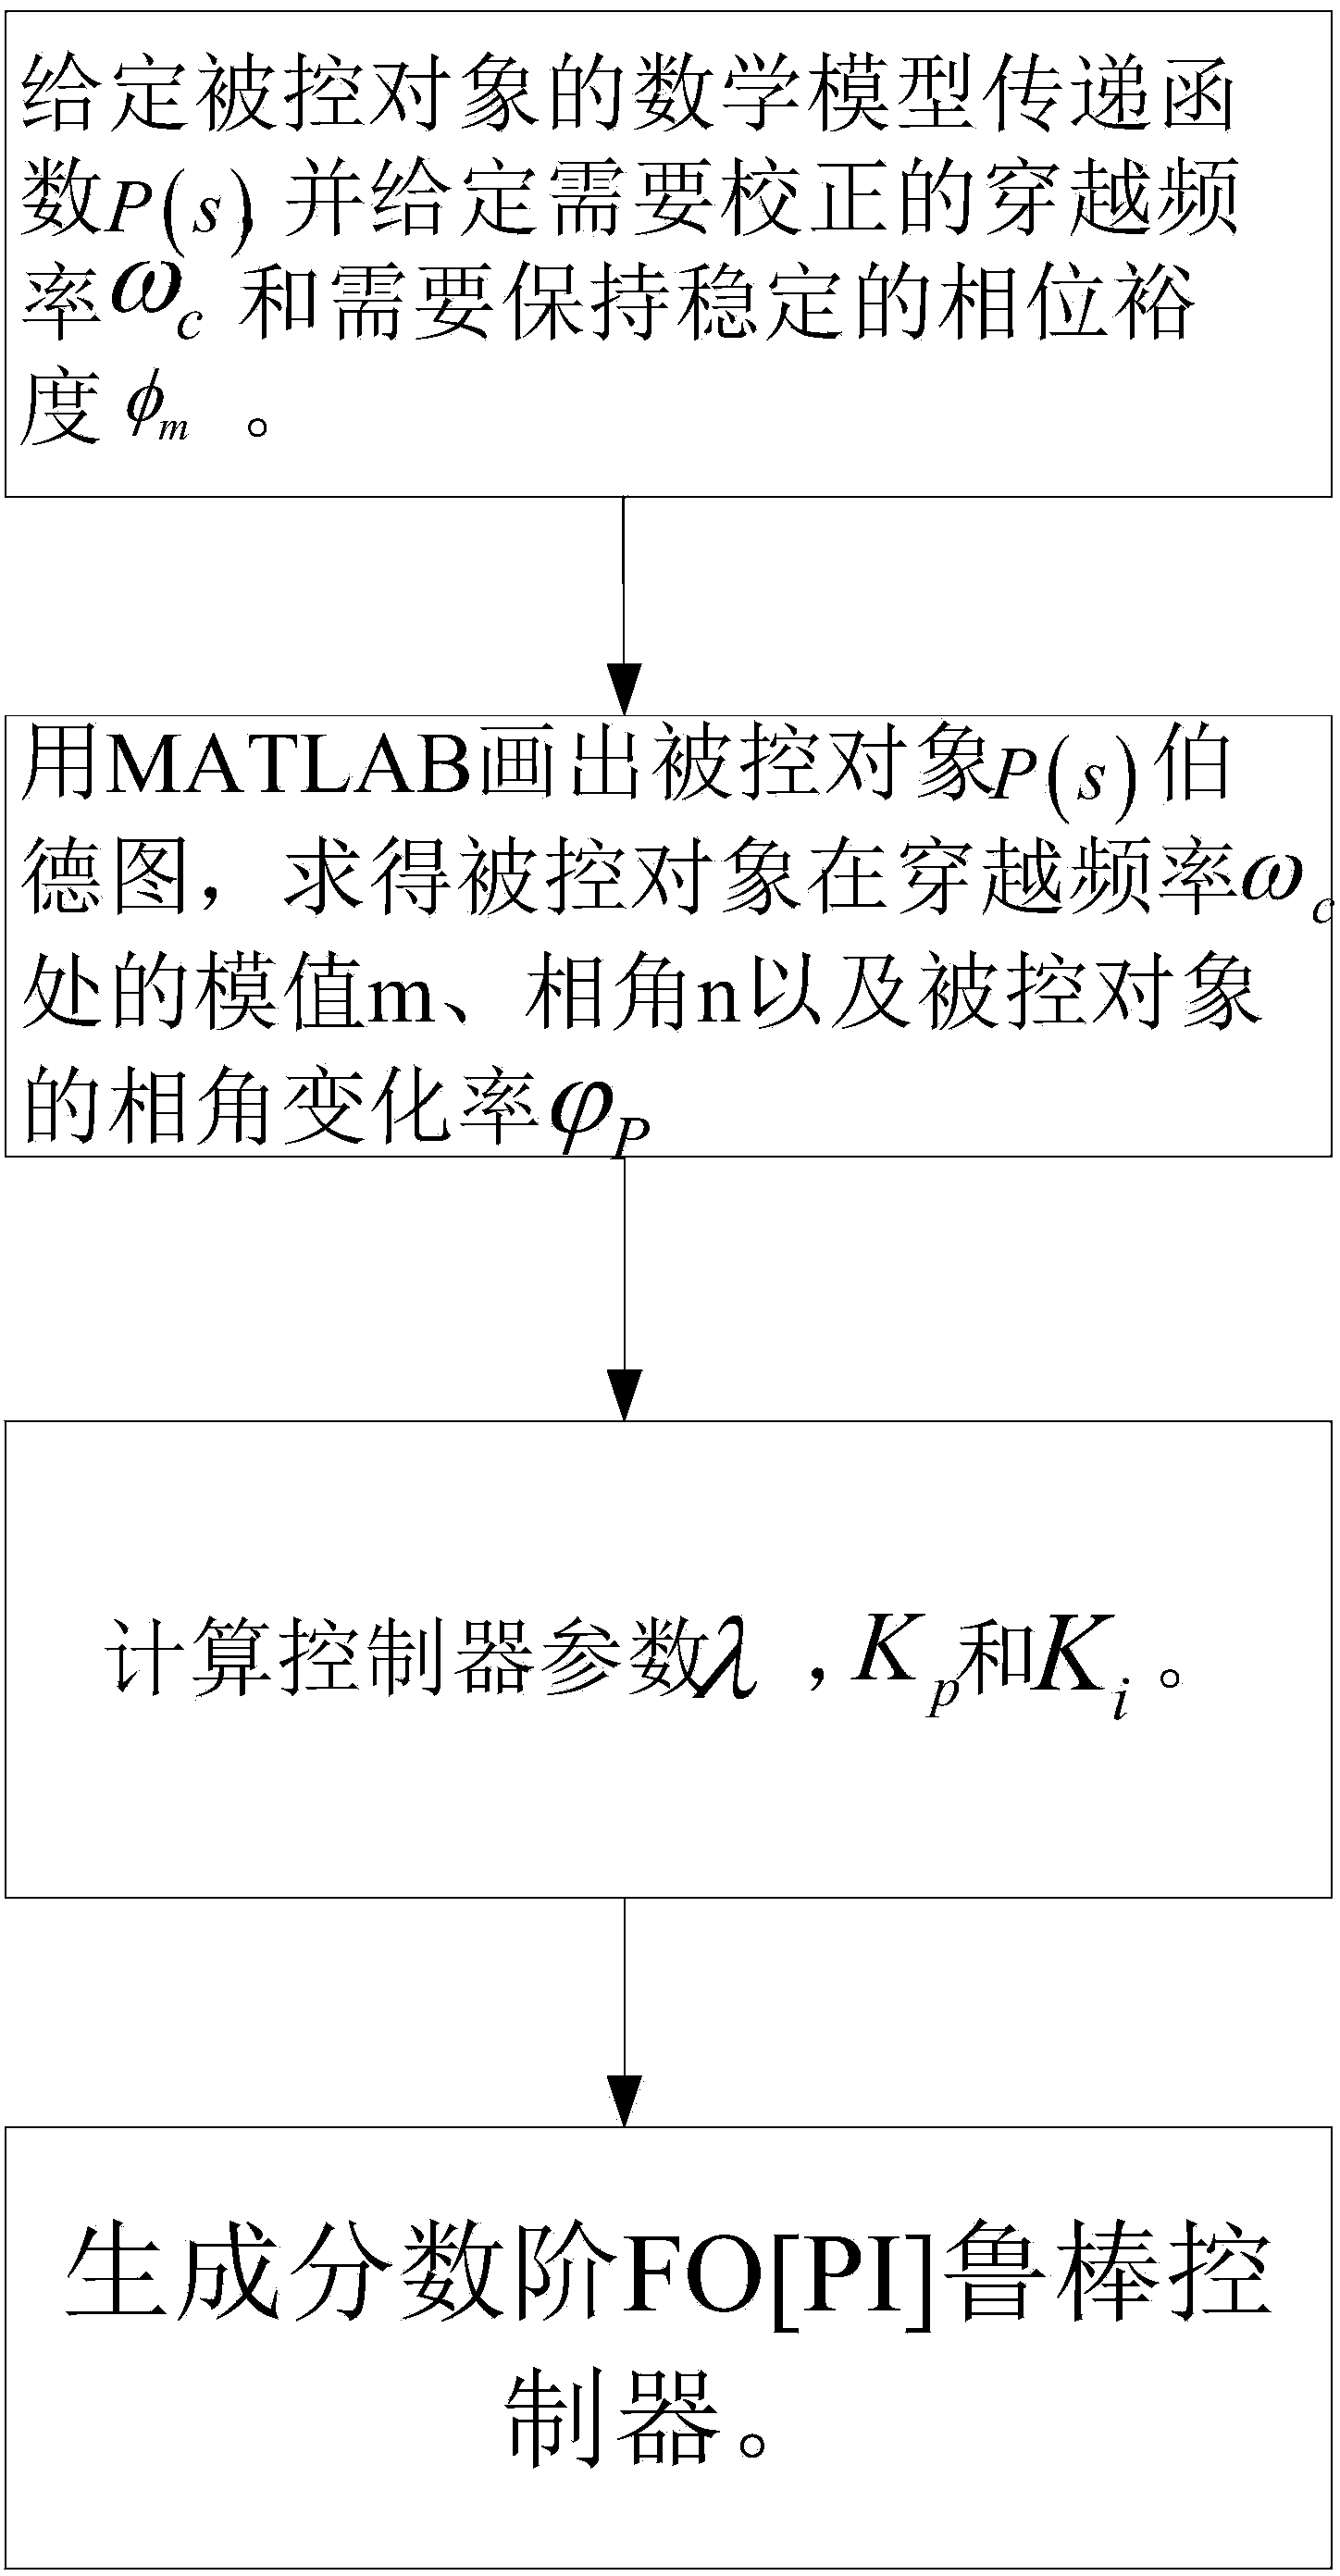
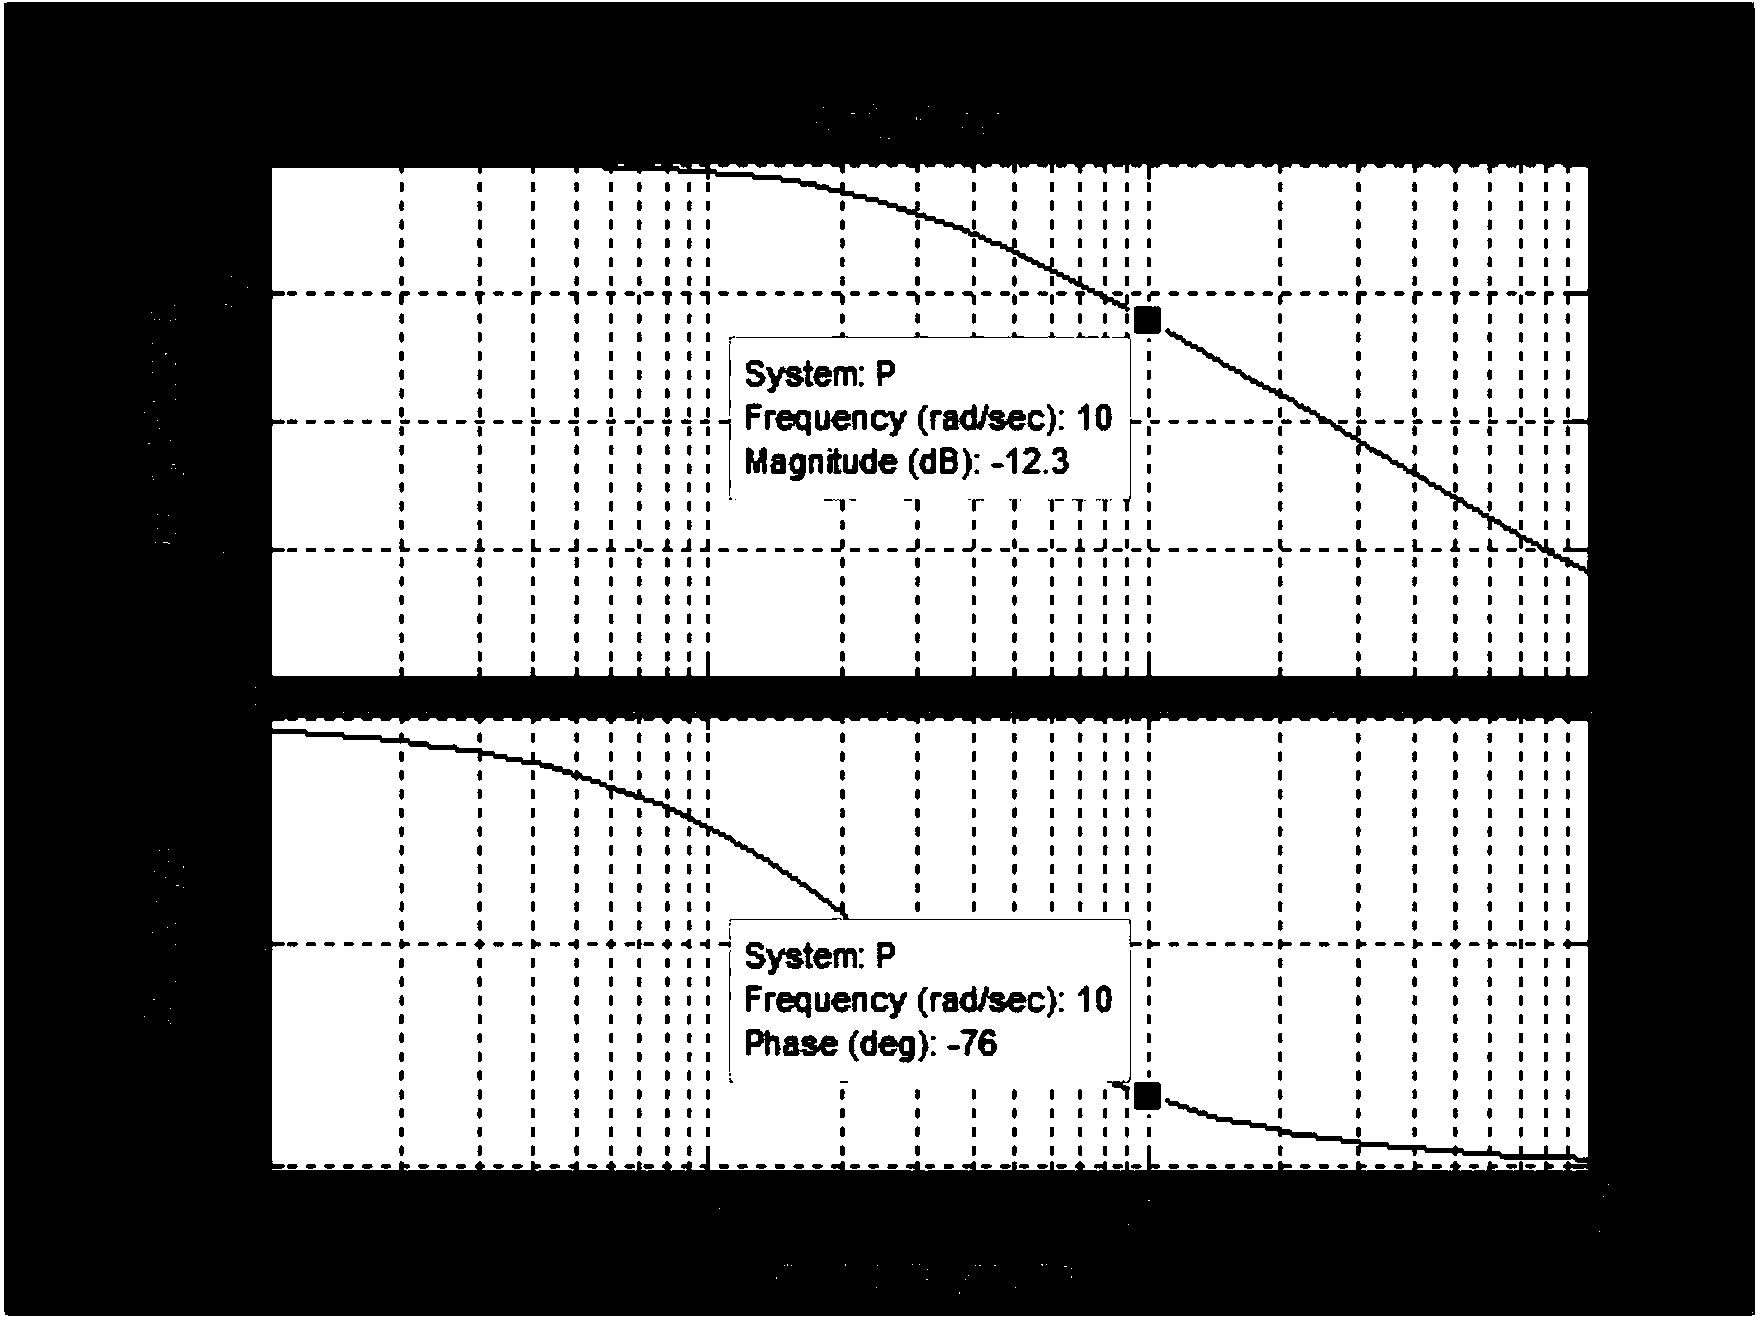
The invention relates to a parameter setting method for a robust controller of a direct current motor, and belongs to the technical field of automatic fractional order control. The parameter setting method is applied to the direct current motor in a position servo system. The transfer function is that , the transfer function of the FO[PI] controller to be subjected to setting is that , the Bode diagram of the controlled object P(s) is drawn up through a MATLAB, the module value m and the phase angle n at the frequency are obtained; through C(s)P(s)=G(s), the equation about integral order lambda is solved through the MATLAB, through the stability condition, the proportionality coefficient and the differential coefficient are solved, through the obtained lambda, the obtained Kp and Ki are substituted into the formula that . The parameter setting method has the advantages that the calculation amount of the parameter setting of the controller is reduced, and the parameter setting process of the factional order FO[PI] robust controller is simplified.
Owner:CHANGCHUN UNIV OF SCI & TECH
VSC inner loop current control method based on uncertain interference estimation
PendingCN113162021AControl wellEnsure system robustnessDc source parallel operationDesign optimisation/simulationInner loopPower grid
The invention discloses a VSC inner loop current control method based on uncertain interference estimation. The method comprises the following steps: S1, constructing a VSC current mathematical model of a DC power distribution network; s2, standardizing the current in the VSC current mathematical model to obtain a VSC inner loop current uncertainty dynamic model; s3, based on the VSC inner loop current uncertainty dynamic model, obtaining a VSC inner loop current reference model based on uncertainty interference estimation, an error equation based on uncertainty interference estimation and uncertainty and disturbance estimation values; and S4, according to the VSC inner loop current reference model, the error equation and the uncertainty and disturbance estimation values, calculating the control law of the VSC inner loop current. According to the method, the problem of poor anti-interference performance of the VSC inner loop current under traditional PI control can be solved, the robustness of a power grid system is improved, and the parameter setting process of the power grid system is greatly simplified.


Owner:CHONGQING UNIV
Method of making tuning map for controlling device of vehicle
ActiveCN105527109AGood pre-tuned mappingGood tuning mapRegistering/indicating working of vehiclesAutomatic steering controlControl logicAutomotive engineering


Owner:HYUNDAI MOTOR CO LTD +1
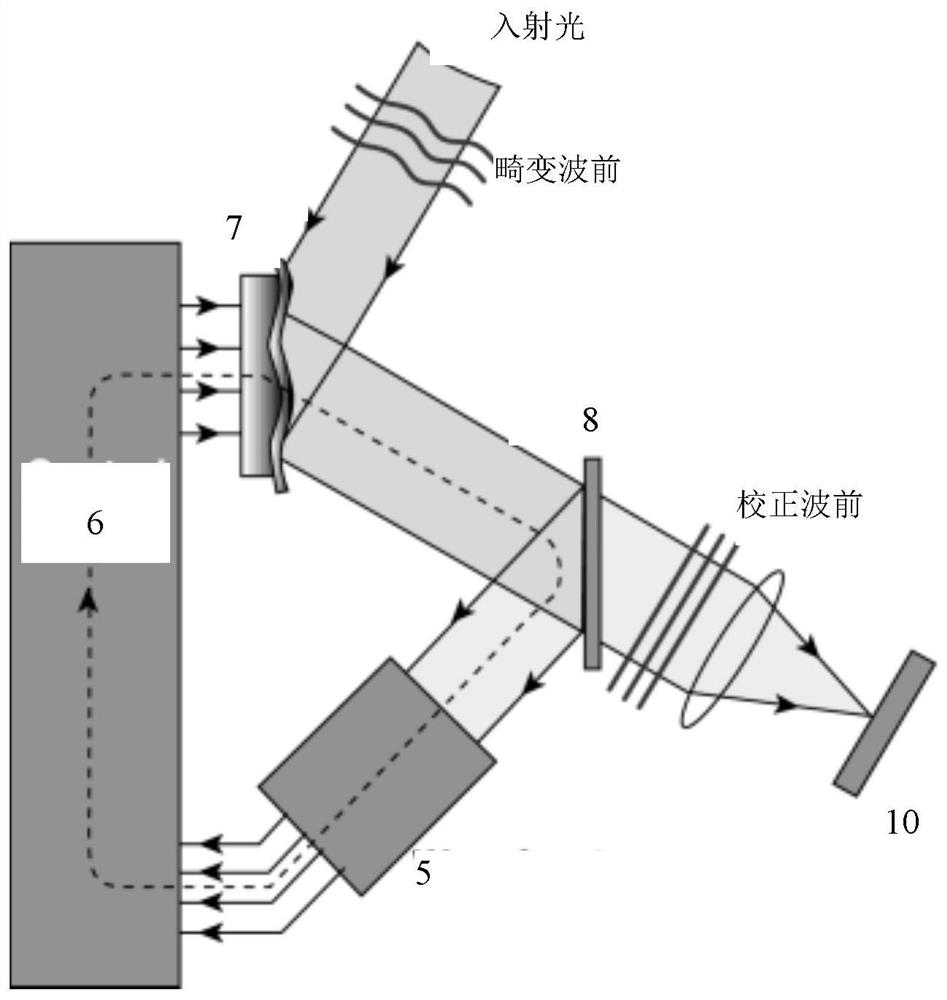
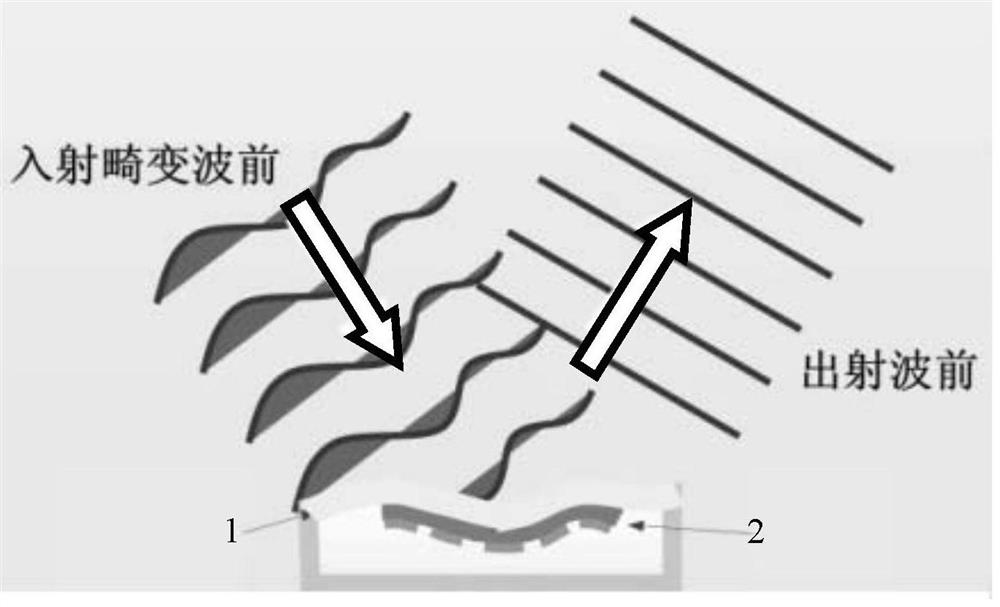
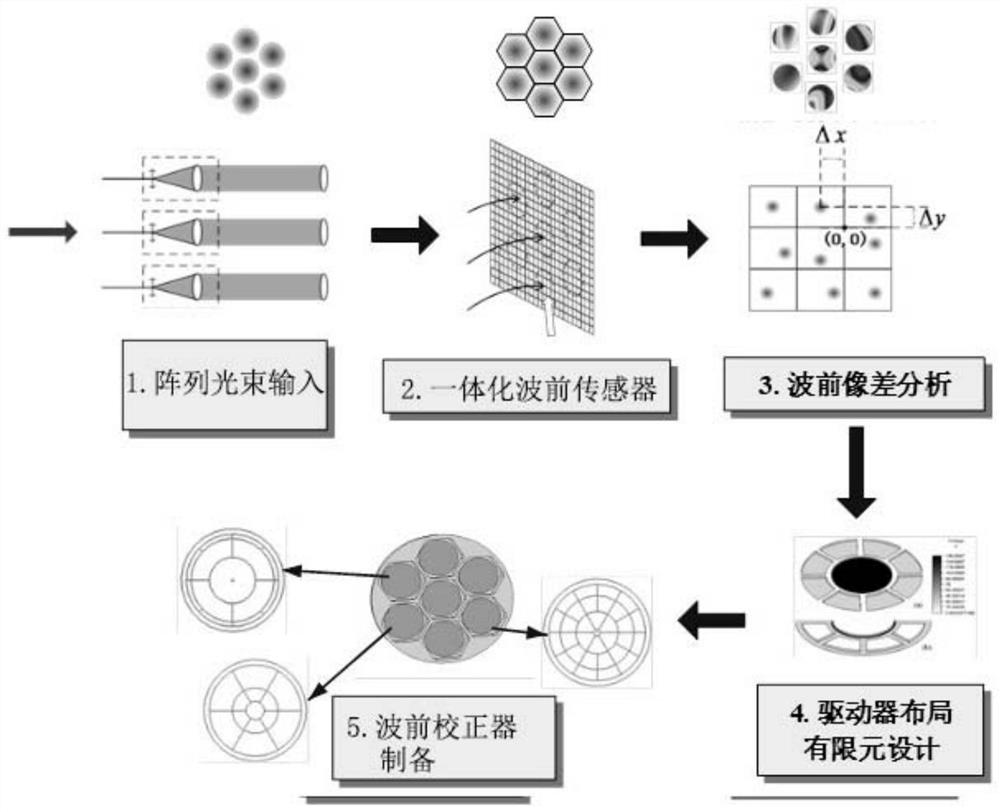
Differentiated array beam wavefront corrector preparation method based on aberration measurement
The invention discloses a differential array beam wavefront corrector preparation method based on aberration measurement. The method comprises the following steps of measuring the distortion wavefront deviation of each sub-beam in an array beam comprising a plurality of sub-beams, and carrying out the three-dimensional modeling of an integrated wavefront corrector through three-dimensional modeling software, importing the model into simulation software for simulation optimization, judging whether the deformation amount and the resonant frequency of each sub-beam deformable mirror of the corrector meet design requirements or not, and if so, recording mirror body structure parameters, otherwise, conducting three-dimensional modeling again, and continuing simulation optimization until the design requirement is met, and preparing the differential wavefront corrector according to the structural parameters of the mirror body. The method has the advantages of low cost, compact system structure, customized design, high correction efficiency and the like.
Owner:NAT UNIV OF DEFENSE TECH
Optimized parameterization of active disturbance rejection control
ActiveCN107077106AReduce oscillationSimplify the tuning processNumerical controlAdaptive controlControl systemActive disturbance rejection control
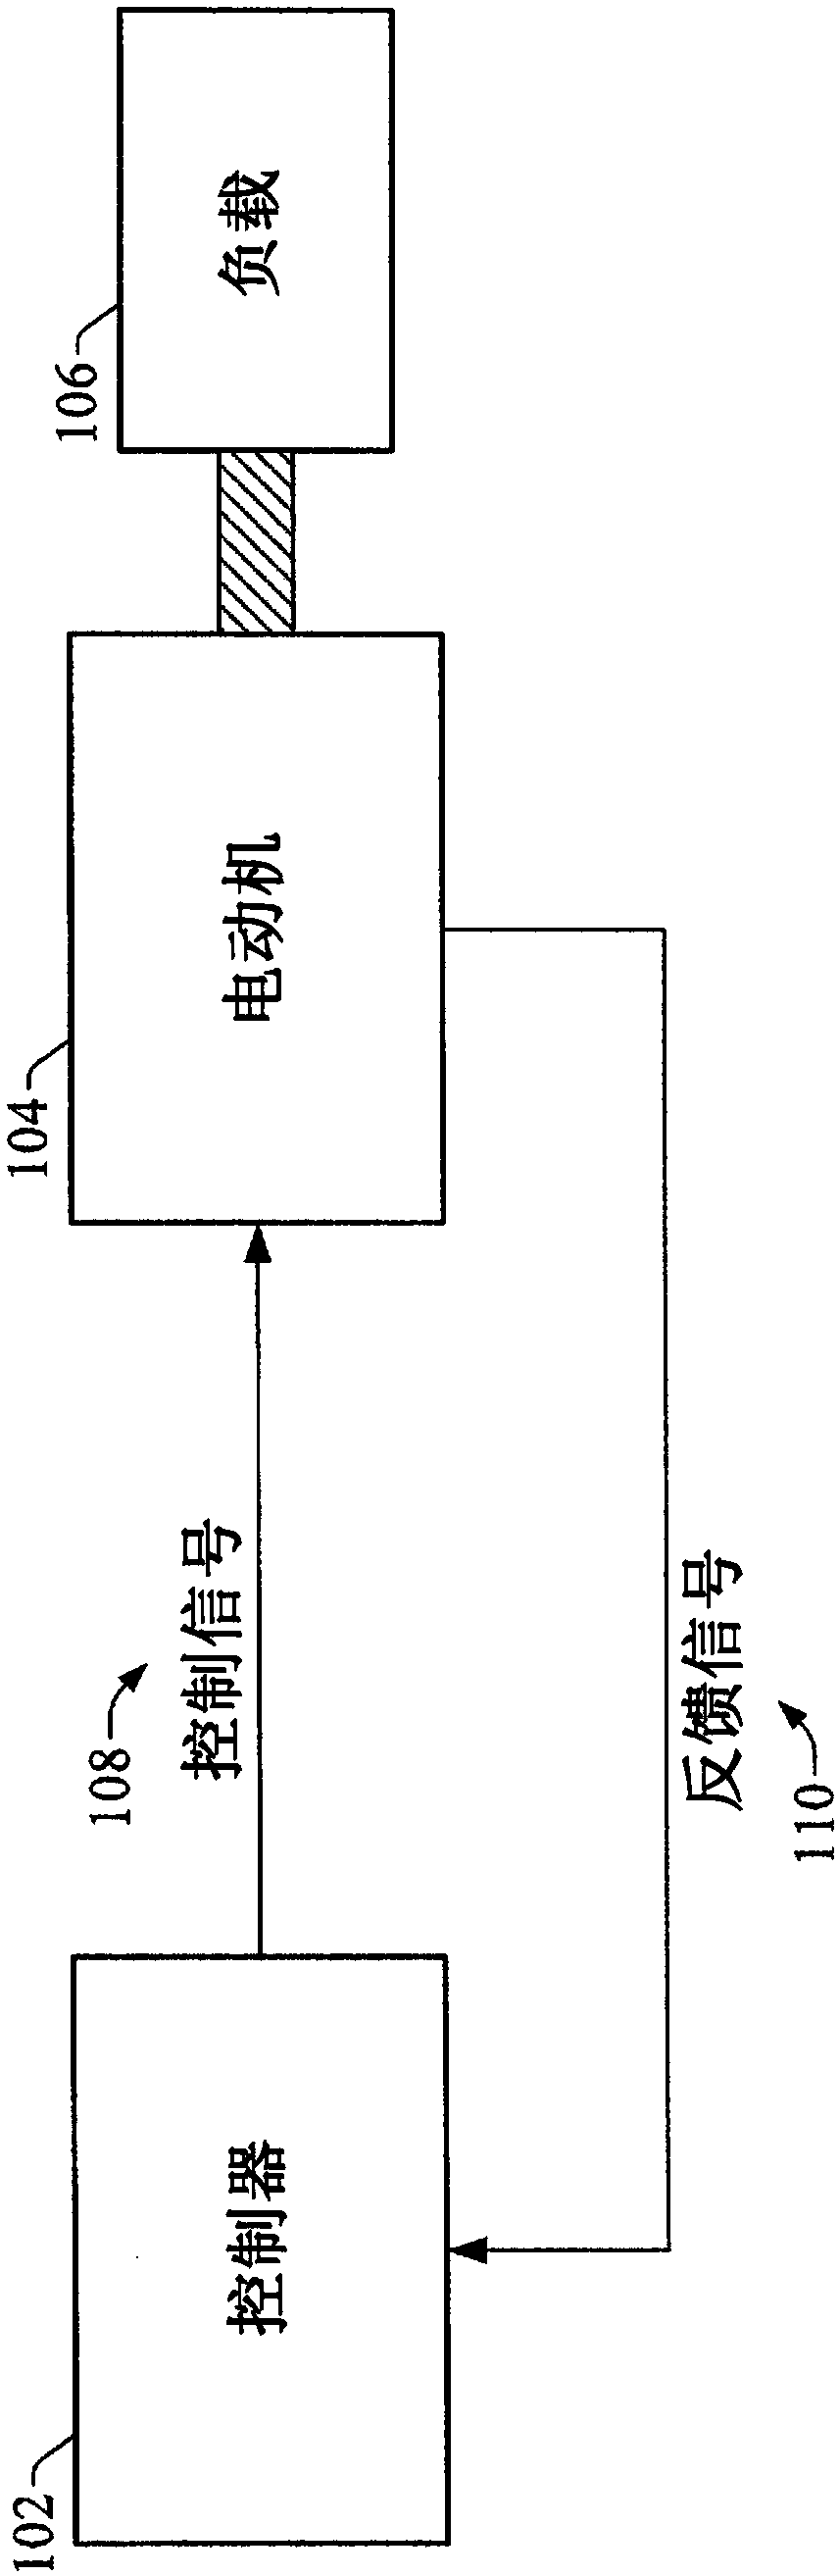
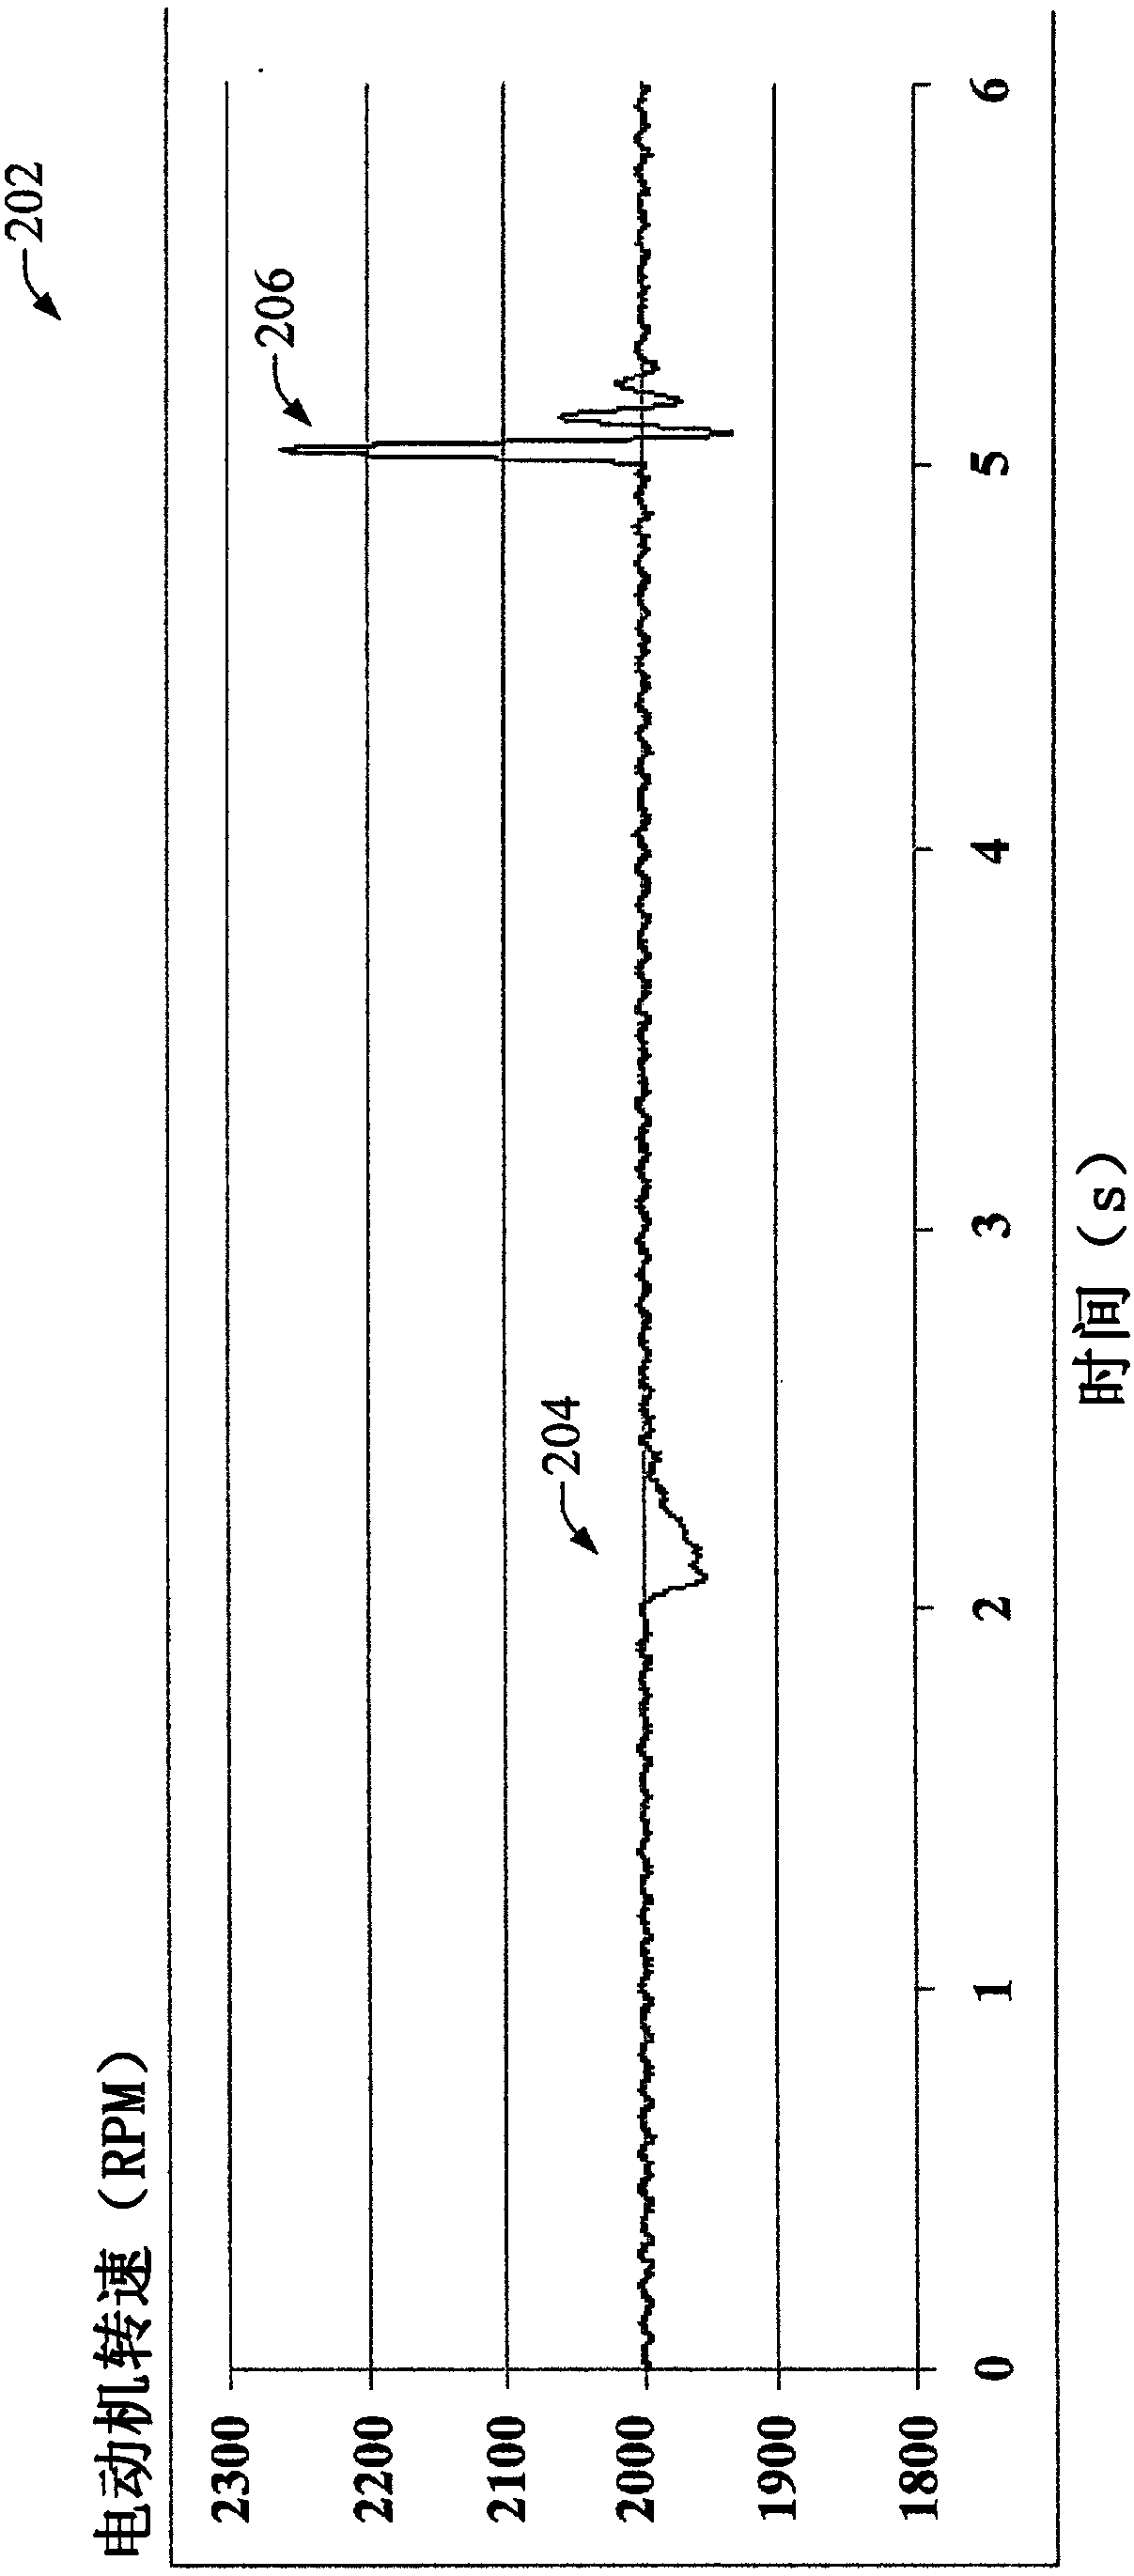
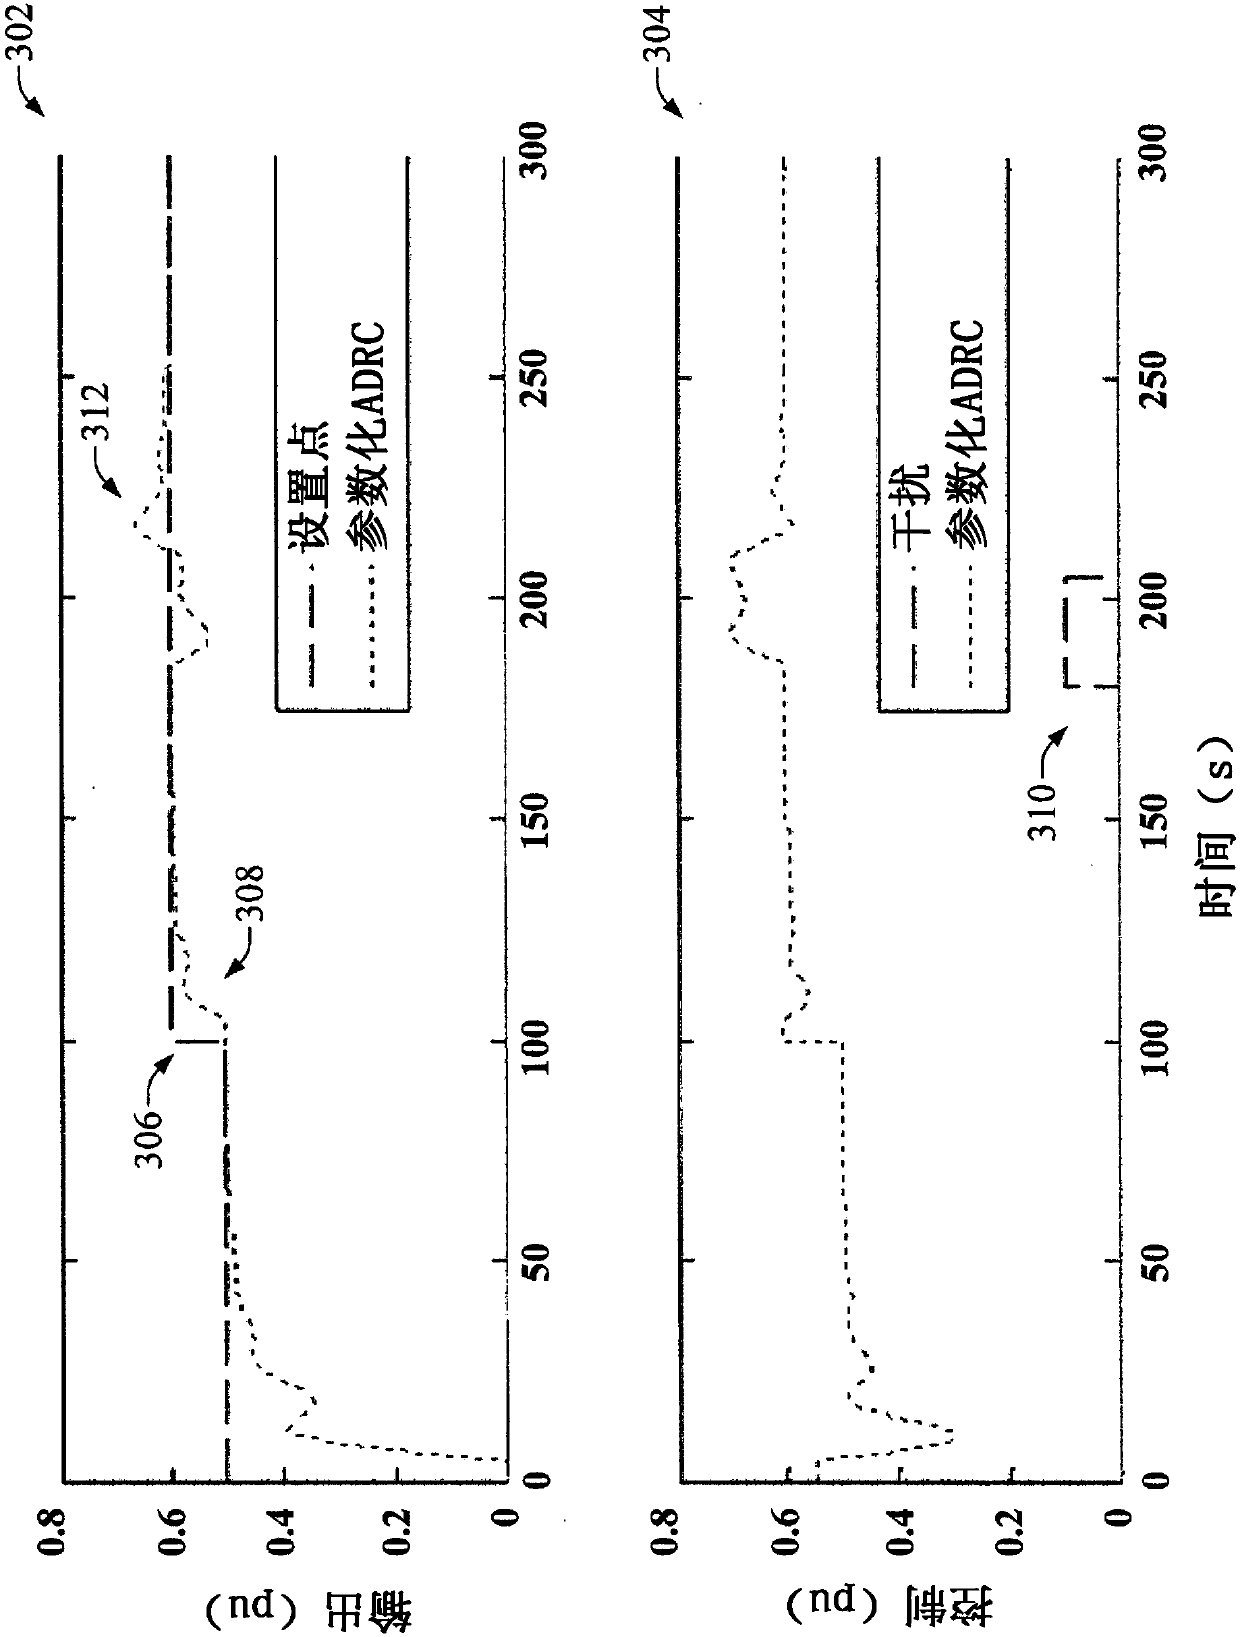
A system for tuning a control system uses a simplified tuning procedure to generate robustly stabilizing tuning parameters that reduce or eliminate undesired system oscillations in the presence of long system dead times or phase lag. A control method is used to establish a relationship between the plant parameters of a controlled system and the tuning parameters of a parameterized active disturbance rejection controller determined to be optimal or substantially optimal for the control system. The plant parameters include the system gain, the time constant, and dead time. Corresponding tuning parameters include the controller bandwidth and a system gain estimate. Using the system gain estimate as a tuning parameter can alleviate the influence of large dead times or phase lags on system response. Once established, these fixed relationships can be used to determine suitable tuning parameters for specific motion or process control applications based on the system gain and dominant constraints of the system.
Owner:DANFOSS POWER ELECTRONICS AS
Setting method for control loop gain of servo system
ActiveCN106788035ASimplify the tuning processImprove automationElectronic commutation motor controlVector control systemsMechanical resonancePosition loop
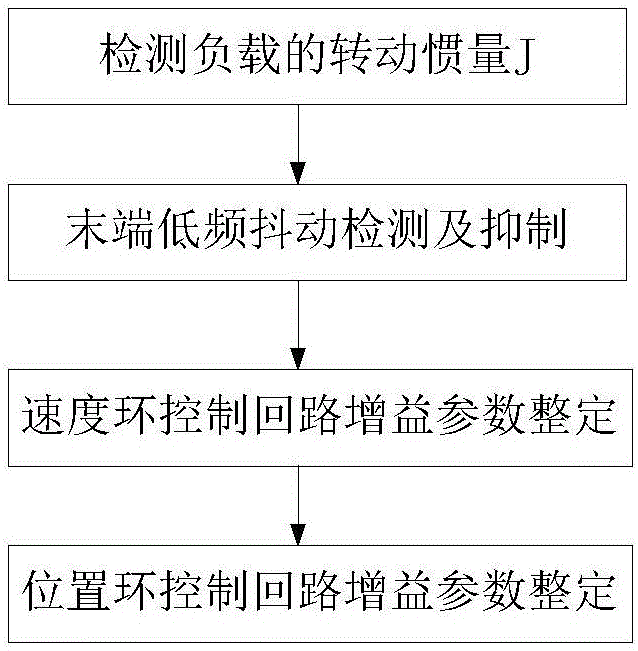
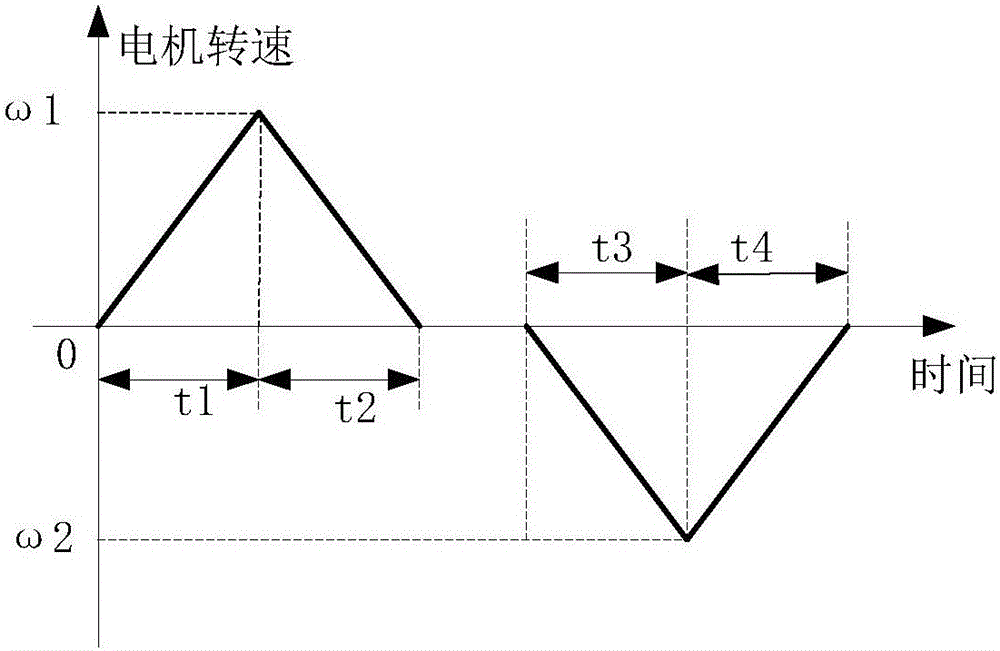
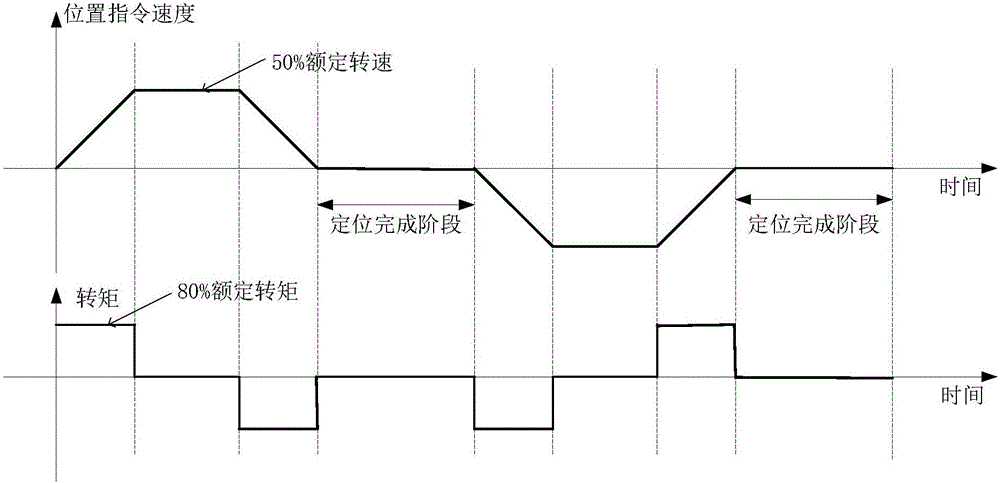
The invention discloses a setting method for the control loop gain of a servo system. The setting method is characterized in that the servo system automatically sets gain parameters of servo control loops during reciprocating motion, specifically the gain parameters of a position loop control loop and a speed loop control loop. The method comprises the following steps: before starting of the setting, firstly determining a simplified load model parameter, namely, determining a rotational inertia J of a load; secondly, performing tail-end low-frequency jitter detection and suppression; thirdly, setting the gain parameters of the speed loop control loop; finally, setting the gain parameters of the position loop control loop. By adopting the method, the servo system can automatically set the gain parameters of the servo control loops, including a position loop proportional gain Kp, a speed loop proportional gain Kv, a position loop integral time constant Ti and a torque filter time constant Tf, during the reciprocating motion; moreover, the low-frequency jitter suppression at the tail end of the load and vibration suppression of mechanical resonance are finished, the tuning process of the servo system is simplified effectively, and the automation degree and intelligence level are increased.
Owner:NANJING ESTUN AUTOMATION CO LTD
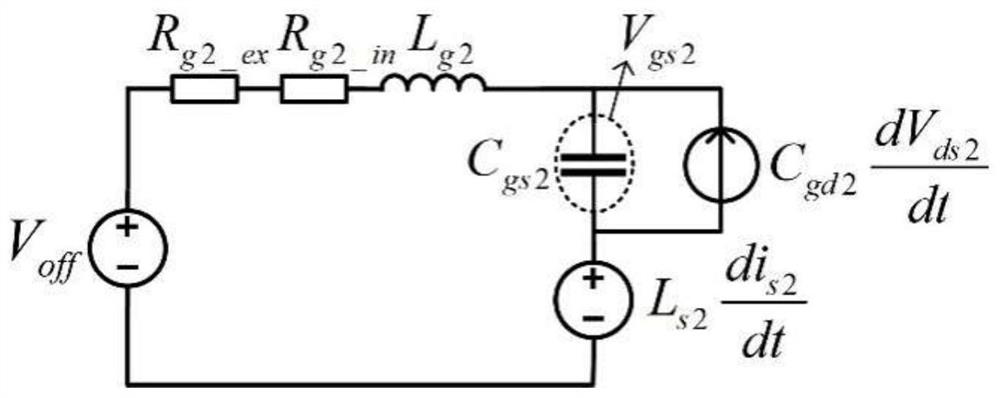
SiC MOSFET crosstalk voltage calculation, parasitic parameter extraction and driving parameter setting method
ActiveCN112491253ASimplify the tuning processShorten the timeEfficient power electronics conversionElectronic circuit testingMOSFETSoftware engineering
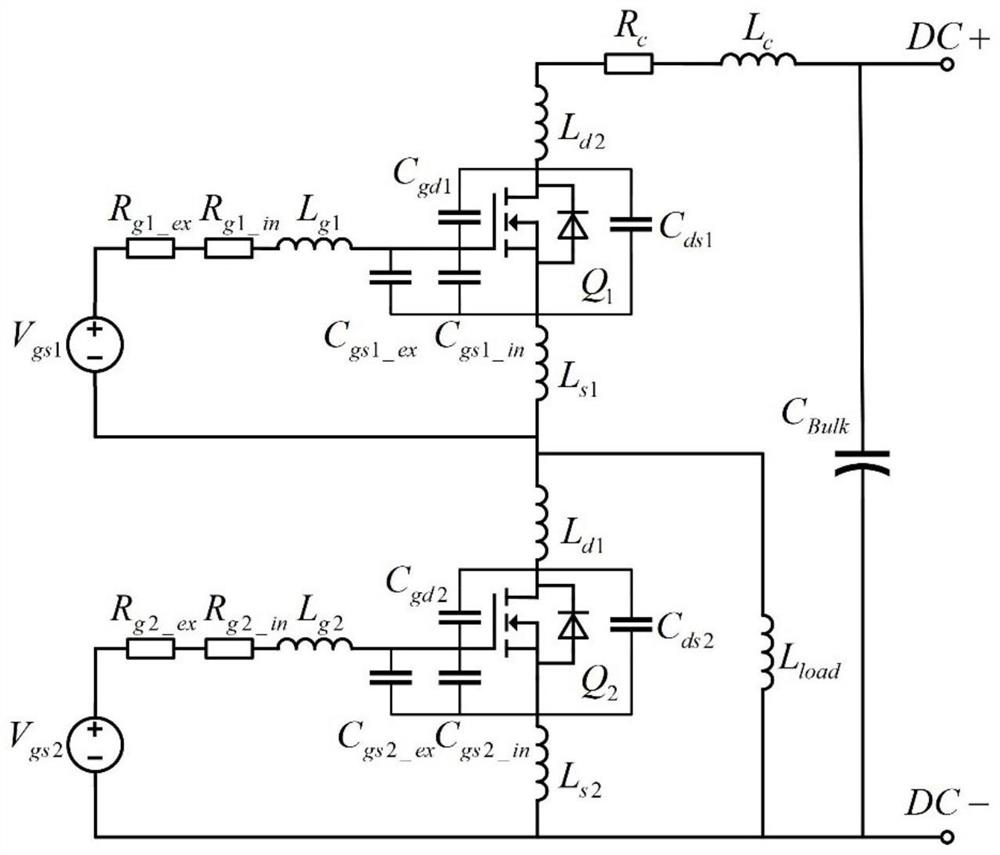
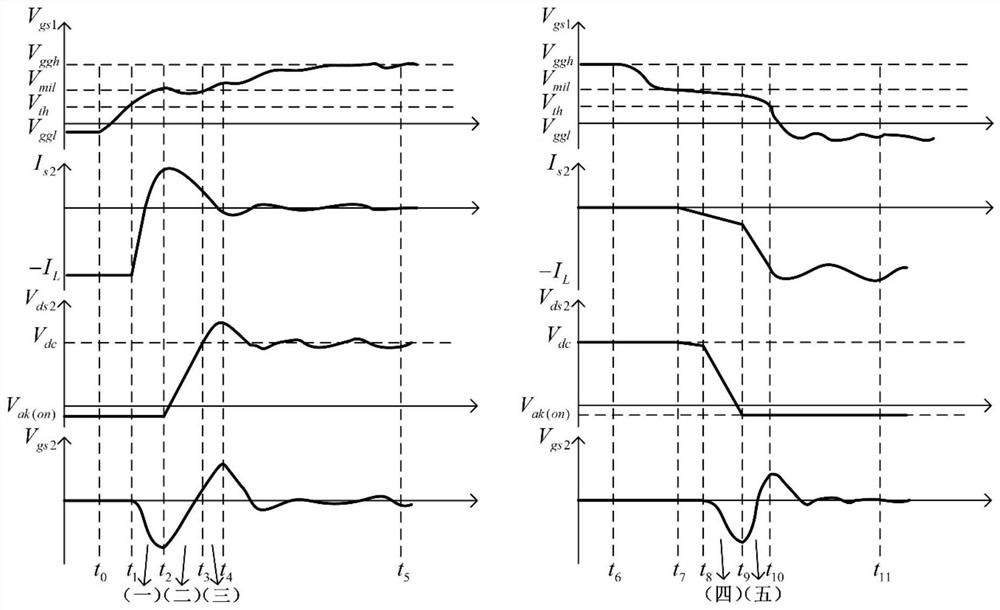
The invention discloses a SiC MOSFET crosstalk voltage calculation, parasitic parameter extraction and driving parameter setting method, and belongs to the technical field of wide bandgap semiconductor device driving. According to the technical scheme, the SiC MOSFET crosstalk voltage model considering the common-source inductance is simplified, a SiC MOSFET crosstalk voltage model is combined with an actual crosstalk voltage suppression method, a driving loop lumped parameter combination with the best crosstalk voltage suppression effect is found through an optimization solution method, timeand devices consumed by repeatedly replacing elements for double-pulse testing in the hardware debugging stage are greatly reduced, the hardware design efficiency is improved, and the parameter setting process is simplified.
Owner:HUAZHONG UNIV OF SCI & TECH
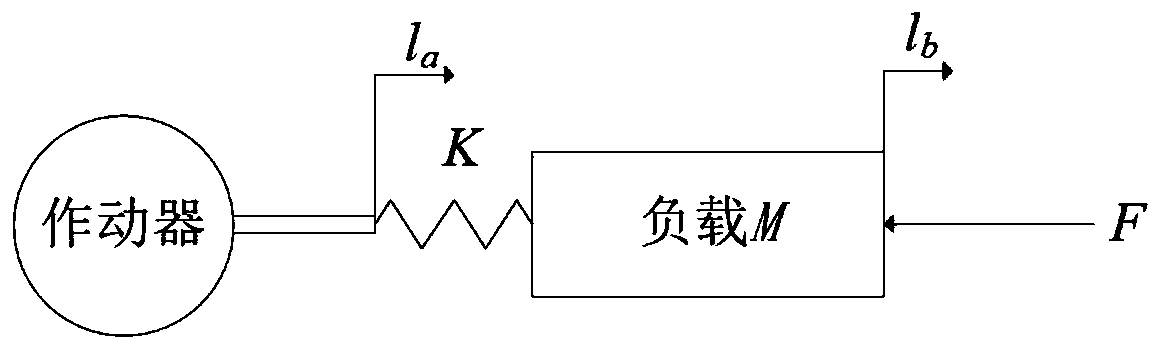
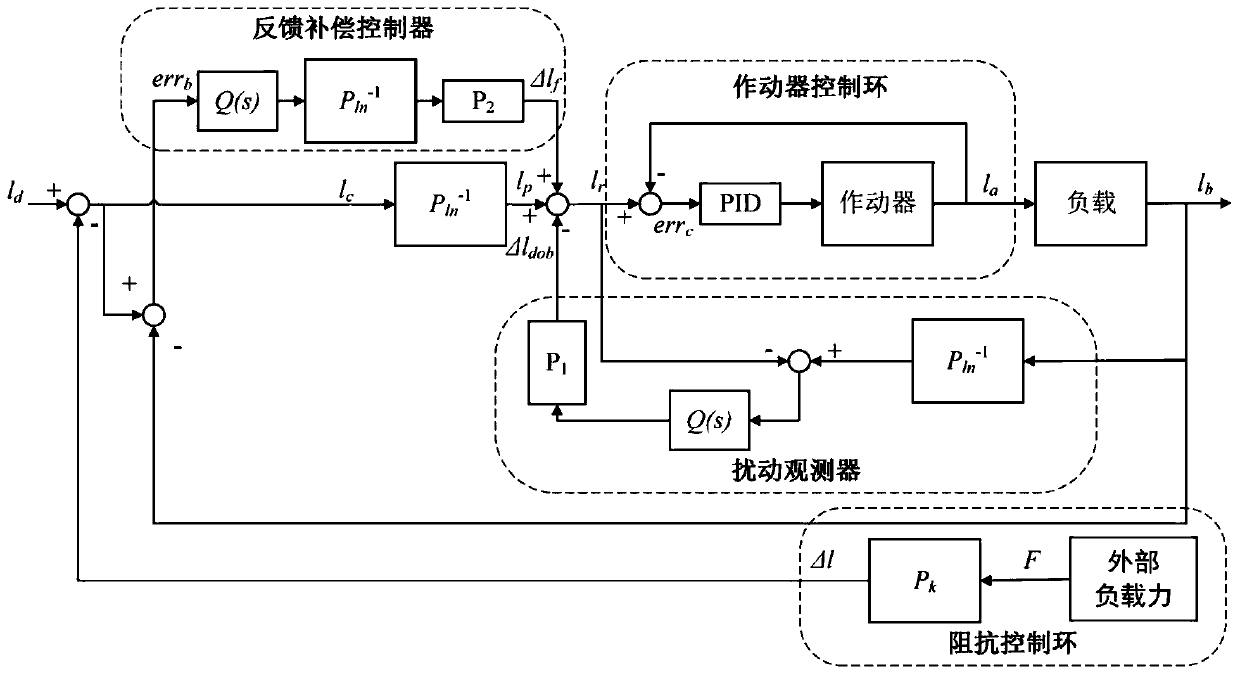
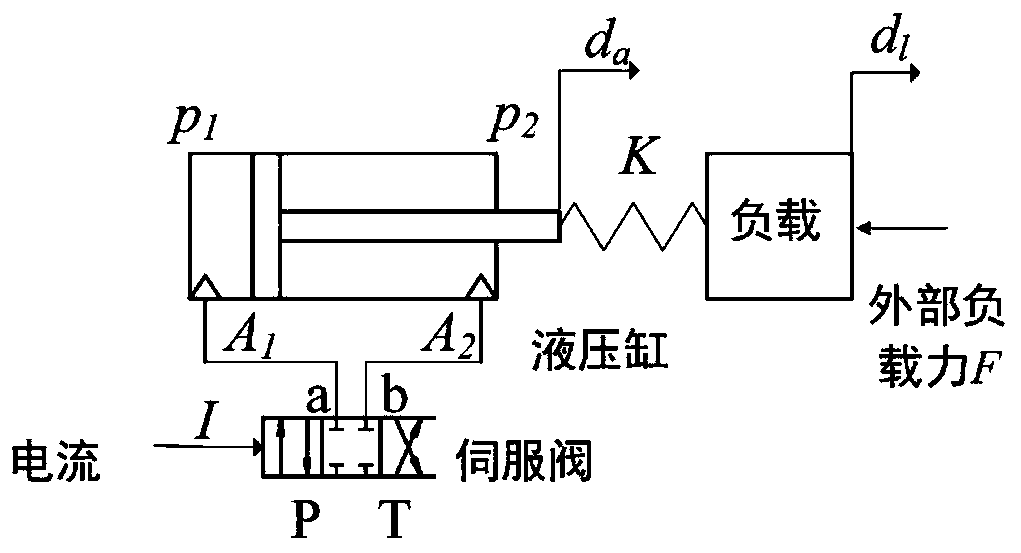
Compensation-based compliance control system and method for series elastic actuators
ActiveCN110561427AAvoid Load ModelingRealize high precision and smooth controlProgramme-controlled manipulatorDynamic modelsControl system
The invention belongs to the field of compliance control over robots, and particularly discloses a compensation-based compliance control system and method for series elastic actuators. The method comprises the following steps of obtaining l<c><t> according to an impedance model P<k> and the preset target positions / angles l<d><t> of load ends of the series elastic actuators at the current moment; obtaining delta l<dob><t> according to inverse nominal models P<ln><-1> of load dynamic models of the series elastic actuators and the actual positions / angles l<t> of the load ends of the series elastic actuators at the current moment; obtaining delta l<f><t> according to l<c><t> and l<t>; and calculating to obtain l<t> according to l<c><t> and P<ln><-1>, calculating the actual target positions / angles l<r><t> of actuation units at the current moment t based on delta l<dob><t>, delta l<f><t> and l<t>, and finally controlling the actuation units of the series elastic actuators to track the actual target positions / angles l<r><t> in real time so as to realize real-time tracking of the target impedance by the series elastic actuators. The control system and method have the advantagesof being capable of realizing the compliance control over the series elastic actuators, high in control precision, good in effect and the like.
Owner:HUAZHONG UNIV OF SCI & TECH
A Rotor Position Identification Method for Permanent Magnet Synchronous Motor in Low Speed Range
ActiveCN110429886BImprove stabilityFast convergenceElectronic commutation motor controlElectric motor controlIntegratorSquare waveform
The invention discloses a rotor position identification method in a low-speed range of a permanent magnet synchronous motor, which belongs to the field of permanent magnet synchronous motor control. In order to solve the problem that the use of multiple filters in the traditional pulse vibration signal injection method causes the superposition of hysteresis effect, the decrease of the dynamic performance of the system and the increase of the position estimation error. The present invention proposes a new low-speed position sensorless control strategy, specifically on the basis of injecting the high-frequency pulse vibration square wave voltage signal into the two-phase stationary coordinate axis system, through a generalized second-order integrator (SOGI) to β The current in the shaft is subjected to signal separation and amplitude demodulation to obtain two orthogonal signals containing rotor position information, and then the rotor position information is extracted by heterodyne method and rotor position observer. No filtering is used in the whole signal demodulation process device. The dynamic performance of the control system and the estimation accuracy of the rotor position are effectively improved.
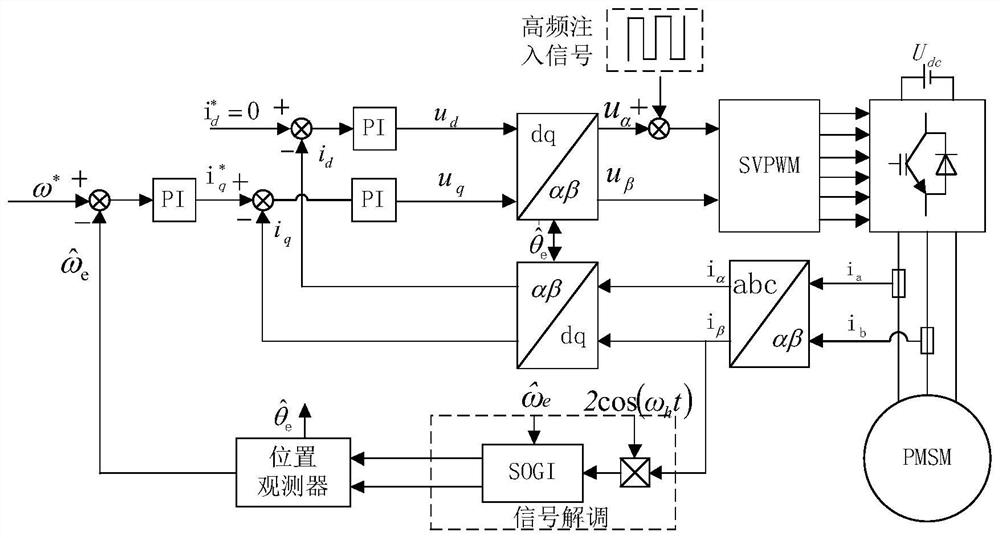
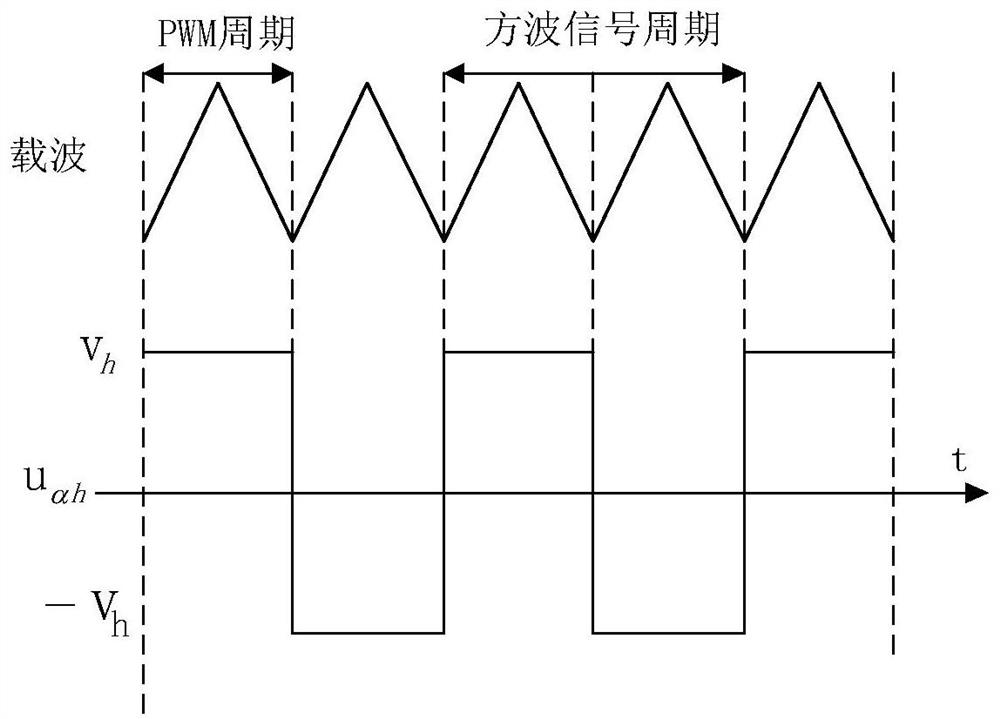
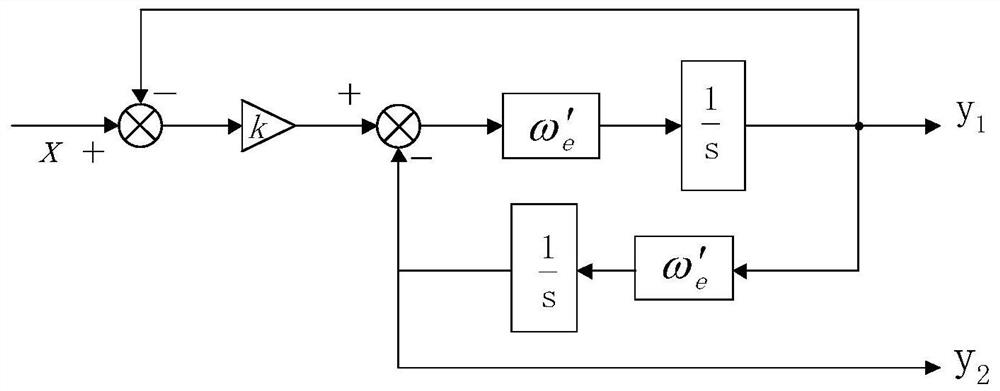
Owner:JIANGSU UNIV
System for initially generating stabilized in-chip clock
ActiveCN101436086BReduce usageLow costPulse automatic controlGenerating/distributing signalsDiscriminatorPhase detector
The invention discloses a system for generating on chip clock of a stabilizer fin through initialization, which comprises a chip provided with a clock automatic locking - integrated circuit configuration IP, a crystal oscillation clock source, a nonvolatile memory and a light-emitting diode, wherein the clock automatic locking - integrated circuit configuration IP comprises a phase discriminator,a charge pump, an analog-to-digital converter, a register, a digital-to-analog converter, a current / voltage controlled oscillator and a frequency locking detection circuit; the crystal oscillation clock source is connected with the input at one end of the phase discriminator; the phase discriminator, the charge pump, the analog-to-digital converter and the register are connected in turn; the register is also connected with the digital-to-analog converter and the nonvolatile memory; and the output of the digital-to-analog converter is connected with the input of the current / voltage controlled oscillator, and the output of the current / voltage controlled oscillator is connected with the input on the other end of the phase discriminator, so as to form a circuit; and both output of the crystaloscillation clock source and the output of the current / voltage controlled oscillator are connected with the frequency locking detection circuit. The system can greatly simplify the correction and regulation flow and reduce the cost.
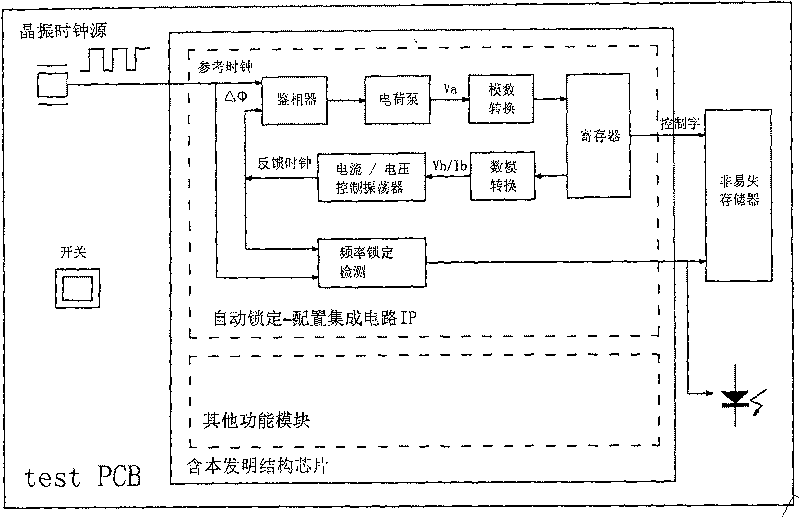
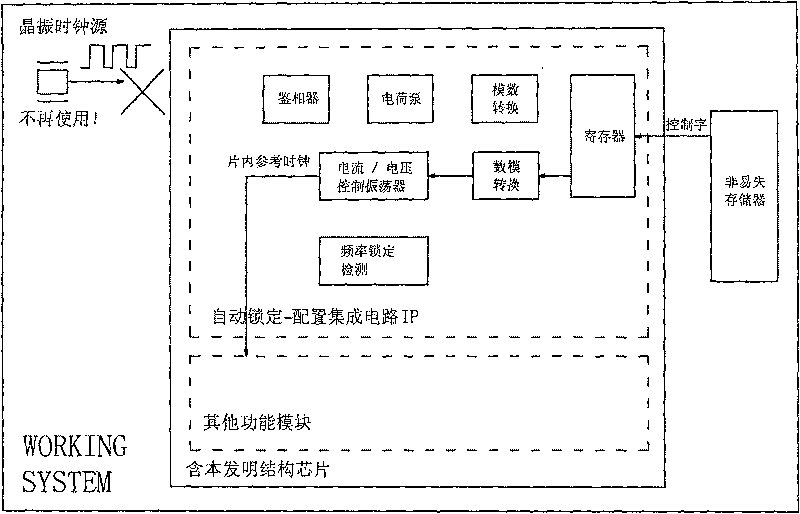
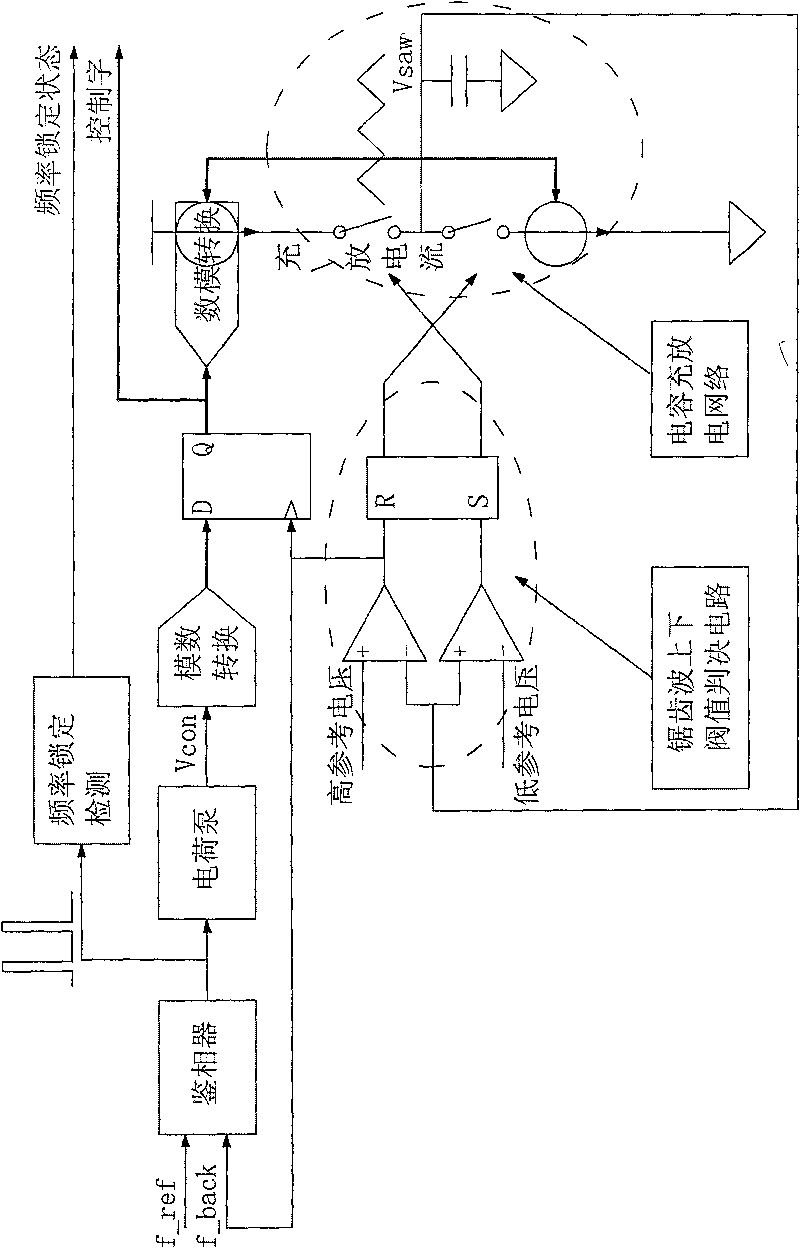
Owner:PHICOMM (SHANGHAI) CO LTD
Listed company risk assessment method based on cross validation and Bayesian optimization
PendingCN119624097AImprove tuning efficiencyreduce consumptionEnsemble learningManufacturing computing systemsPrincipal component analysisDimensionality reduction
The invention discloses a listed company risk assessment method based on cross validation and Bayesian optimization, and the method comprises the following steps: 1, obtaining the comprehensive factor data of a listed company, carrying out the dimension reduction of the factor data through employing a principal component analysis method, obtaining a principal component factor, carrying out the effectiveness verification of the principal component factor through an IC and IR analysis method, and carrying out the calculation of the risk of the listed company; selecting a plurality of principal component factors as input features; 2, on the basis of the multi-factor model, constructing an ensemble learning index enhancement model by taking a decision tree and an AdaBoost algorithm as cores; 3, performing system optimization on parameters of the ensemble learning index enhancement model by adopting cross validation and a Bayesian method, and finally determining an optimal parameter combination to obtain a trained ensemble learning index enhancement model; and 4, evaluating the risk of the listed company by using the trained integrated learning index enhancement model. According to the method, the calculation resource consumption of the model can be reduced, the calculation efficiency is improved, and the over-fitting risk of the model can be reduced.


Owner:NINGBO UNIV
Robust control method for aircraft attitude angle in predetermined time under unknown disturbance
ActiveCN119535990AOvercome the impact of uncertainty interferenceImprove robustnessSustainable transportationAdaptive controlFlight vehicleKinetics equation
The invention belongs to the technical field of flight control. The invention provides a predetermined time robust control method for an aircraft attitude angle under unknown disturbance. The method comprises the following steps: establishing an attitude angle and angular rate kinetic equation of an aircraft according to wind tunnel experiment data; in consideration of uncertainty and unknown disturbance existing in the kinetic equation, modeling the kinetic equation into a comprehensive disturbance form, and converting the kinetic equation into a ray-imitated form containing disturbance; a preset time disturbance estimator is designed to achieve accurate estimation of comprehensive disturbance, an attitude angle preset time backstepping controller is designed, disturbance is compensated in the controller, and preset time control over the attitude angle of the aircraft is achieved. The method disclosed by the embodiment of the invention has the advantages of simple structure and strong robustness, the parameter adjustment requirement for convergence time is simplified, and the preset time control on the attitude angle of the aircraft under the condition of unknown disturbance can be realized.

Owner:NORTHWESTERN POLYTECHNICAL UNIV
Power grid phase detection system and method
InactiveCN108152588AStrong inhibitory effectReduce the impactVoltage-current phase anglePower gridPhase-locked loop
The invention discloses a power grid phase detection system. The system comprises a voltage detection link, a lowpass filtering link, a notch link, and further comprises an amplitude detecting link, and the lowpass filtering link and the notch link are embedded in a phase-locked loop; the invention further includes a phase detection method. According to the system and the method, through the embedded lowpass filtering link and notch link, low-frequency, medium-high-frequency harmonic components of power grid voltage are suppressed and the process of controller tuning is simplified without considering the influence of phase delay.

Owner:WUHAN MARINE ELECTRIC PROPULSION RES INST CHINA SHIPBUILDING IND CORP NO 712 INST
Suspension stiffness adjustable mechanism
ActiveCN106379153AContinuous operationSimplify the tuning processJet propulsion mountingInternal combustion mountingEngineeringMechanical engineering
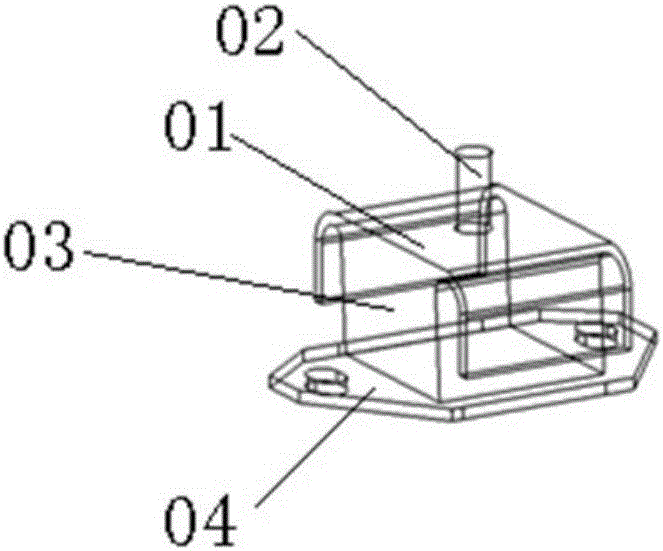
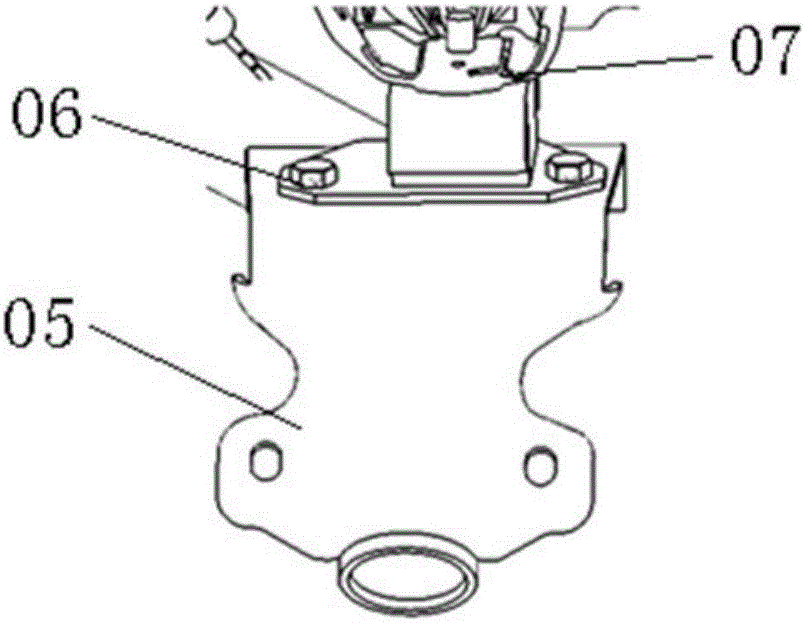
Owner:ANHUI JIANGHUAI AUTOMOBILE GRP CORP LTD
Global fast terminal sliding mode control method based on invariant manifold observer
ActiveCN113377006ASimplify the tuning processEasy and fast parameter adjustmentControllers with particular characteristicsControl engineeringControl theory
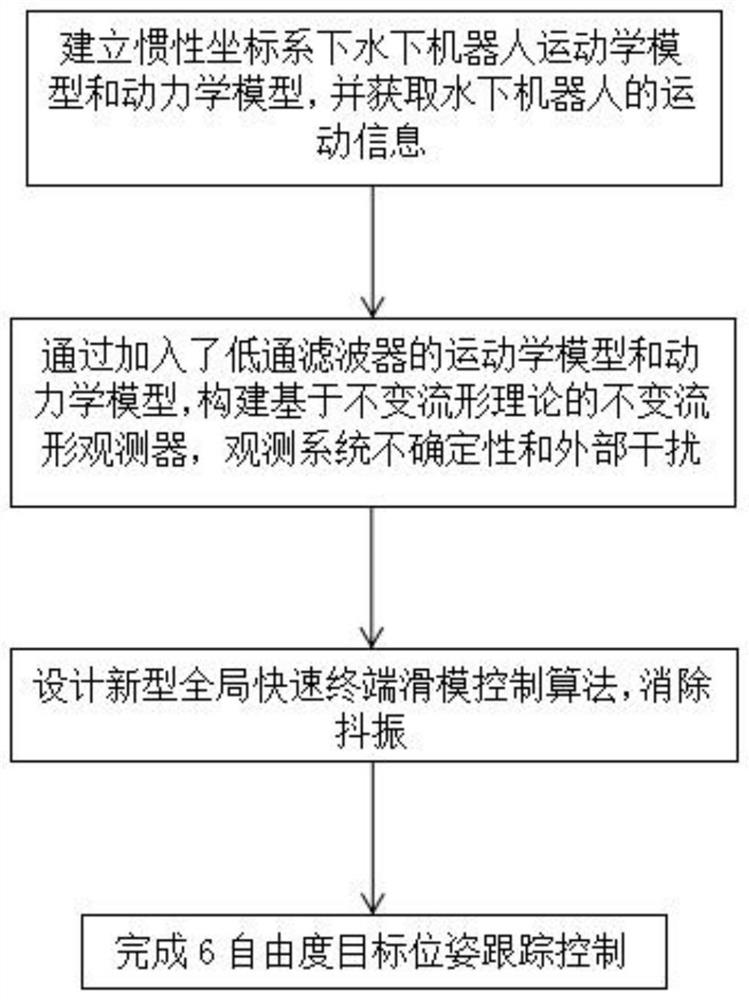
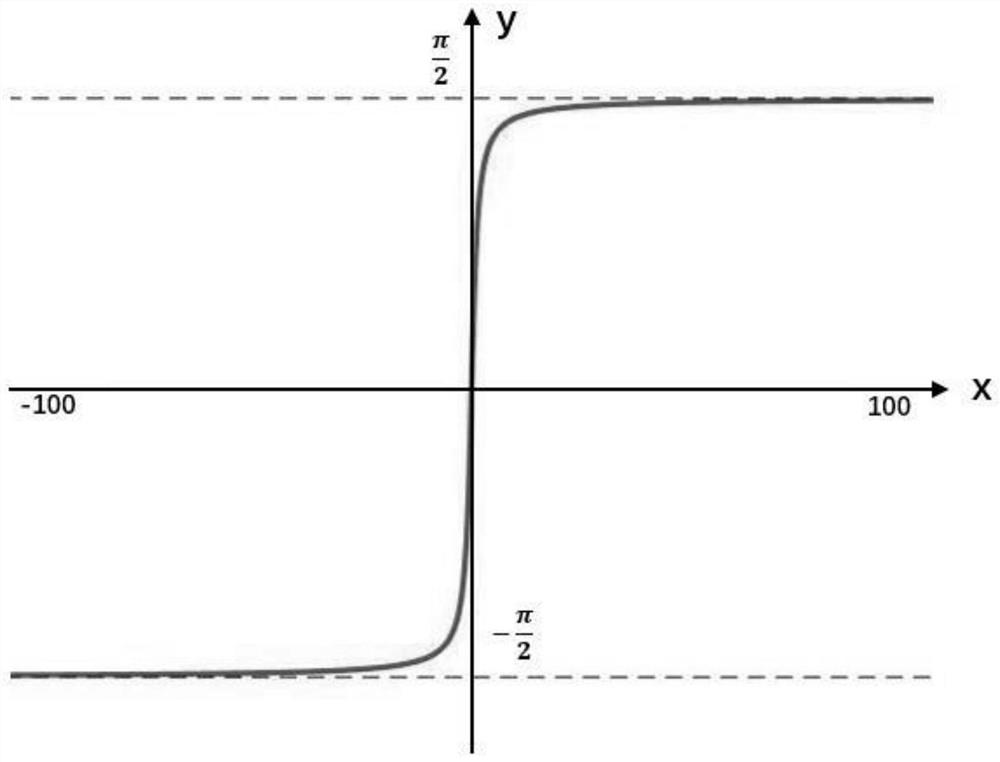
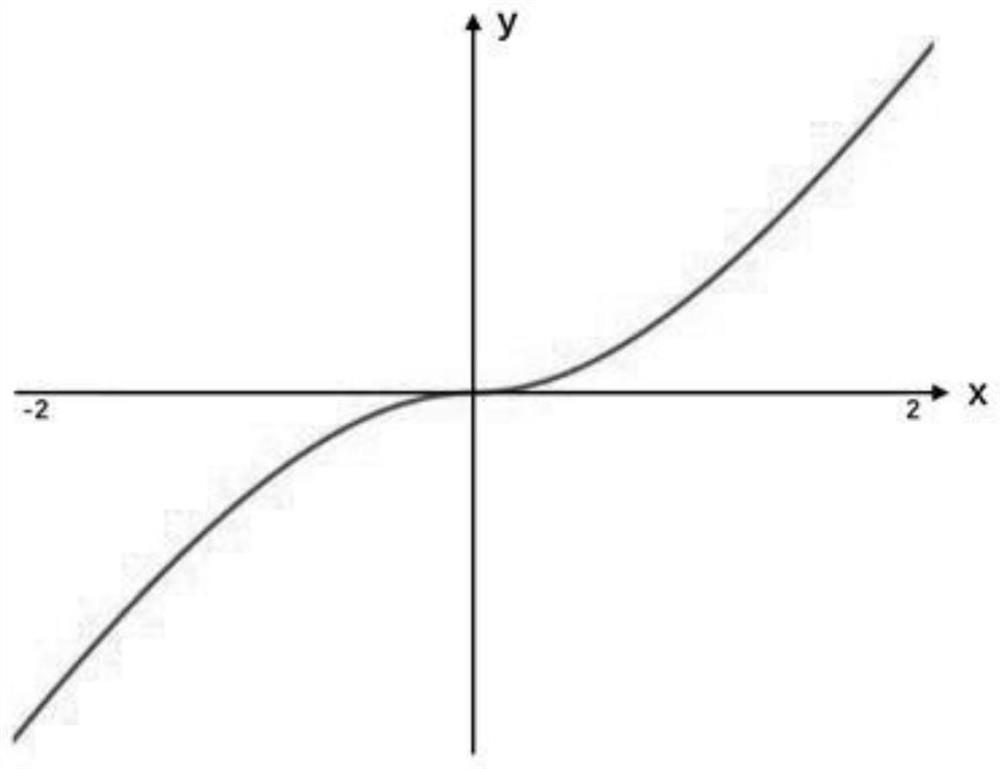
The invention discloses a global fast terminal sliding mode control method based on an invariant manifold observer, relates to underwater robot control, and solves the technical problems of chattering and difficult parameter adjustment of an existing underwater robot. Motion parameters of the underwater robot are analyzed through an invariant manifold observer constructed based on an invariant manifold so as to obtain observation values of system uncertainty and external interference; and a continuous control law used for controlling the underwater robot to move is obtained by analyzing the observation value through a global fast terminal sliding mode control algorithm added with a function item. According to the method, parameter adjustment is simple, the convergence speed is high, the observation error is small, the anti-interference and anti-noise performance of an underwater robot system is effectively improved, the buffeting-free characteristic is achieved, and buffeting is fundamentally eliminated.
Owner:SOUTH CHINA UNIV OF TECH
Aerial interoperation system active disturbance rejection control method based on laser perception
PendingCN119535973Aeasy to controlAccurate and stableInternal combustion piston enginesAdaptive controlThrottle controlPoint cloud
The invention discloses an active-disturbance-rejection control method for an air mutual-control system based on laser perception, and the method specifically comprises the steps: building a kinetic model and a kinematic model of a four-rotor unmanned plane, and taking a mechanical arm as the external disturbance of the unmanned plane; point cloud data around a flying mechanical arm are collected, through accurate segmentation and registration processing, graph optimization is conducted through the processed point cloud data, and therefore the position of the quadrotor unmanned aerial vehicle is accurately positioned; generating a torque instruction for controlling a motion axis of the quadrotor unmanned aerial vehicle according to the position of the quadrotor unmanned aerial vehicle through an integral type active disturbance rejection attitude control strategy improved by PID position control series connection; and according to the lift force and the torque instruction of the four-rotor unmanned aerial vehicle, calculating a throttle control signal corresponding to a propeller to complete control of the four-rotor unmanned aerial vehicle. Pose information is accurately transmitted through a graph optimization framework, the stability and operation precision of the system are remarkably improved in combination with an improved integral type active disturbance rejection control technology, and it is ensured that accurate control and stable maintenance of the unmanned aerial vehicle are achieved in a complex environment.

Owner:SOUTHWEAT UNIV OF SCI & TECH
Optimal fault-tolerant control method and system for robust path tracking of coastal tugboat
InactiveCN119668111AGuaranteed stabilityGuaranteed accuracyAdaptive controlPerformance functionDynamic equation
The invention relates to an optimal fault-tolerant control method and system for coastal tugboat robust path tracking. The method comprises the steps of establishing three-degree-of-freedom tugboat kinematics and dynamics equations, constructing an error system which considers external ocean disturbance and internal propeller faults at the same time according to information of a reference trajectory, constructing a proper discount performance function in combination with the error system, and calculating the discount performance of the tugboat according to the discount performance function. Wherein the discount performance function comprises estimation for external ocean disturbance and internal thruster faults, and an optimal solution of the discount performance function is obtained through de-iterative optimization of an action home-approval home neural network based on an adaptive dynamic programming method. According to the method, tugboat path tracking control under the multi-constraint condition can be overcome, and the parameter setting process is simplified.

Owner:HAINAN UNIV
Multi-domain non-cooperative distributed retrieval result fusion system and fusion method thereof
ActiveCN106897736AEffectively reflect the relevanceImprove fusion accuracyCharacter and pattern recognitionSpecial data processing applicationsFeature extractionComputer module
The invention discloses a multi-domain non-cooperative distributed retrieval result fusion system and a fusion method thereof. The system comprises a data processing module, a feature extraction module, a model training module, a central processing module and a correlation scoring module; the data processing module is used for storing corpus data and cached data needed by the system and providing interfaces for the outside to interact with other modules; the feature extraction module is used for extracting multi-domain features from training corpus or retrieval results; the model training module is used for training a model, wherein the training of the model includes model initialization and model learning; the central processing module is responsible for flow processing of distributed retrieval result fusion and interacting with the other modules and is the implementation part of the core logic of the system; and the correlation scoring module is sued for performing global correlation scoring on query results. With the multi-domain non-cooperative distributed retrieval result fusion system and the fusion method thereof of the invention adopted, the problem of incapability of directly comparing different retrieval results due to the difference of retrieval models under a non-cooperative environment can be solved, and the problem of complex parameter adjustment of a heuristic method can be also solved.


Owner:SOUTH CHINA UNIV OF TECH
Coaxial alignment device and coaxial alignment method
The invention discloses a coaxial alignment device and a coaxial alignment method. The coaxial alignment device comprises a bearing, an adjusting mirror bracket, a display plate to be coaxially aligned, a microscopic system and a platform, an outer ring of the bearing is connected with the platform, an inner ring of the bearing is connected with the adjusting mirror bracket, and the adjusting mirror bracket is located above the bearing; the center of the display plate is provided with a center mark, and the display plate is connected to the center of the adjusting mirror bracket; and the microscopic system is erected above the adjusting mirror bracket and is used for observing the motion trail of the center mark of the display plate in the adjusting mirror bracket. According to the coaxial alignment device and the coaxial alignment method, the high precision of coaxial alignment can be met, meanwhile, the workload of adjustment and calibration personnel can be greatly reduced, the complexity and the cost of the whole mechanical structure are reduced, the external influence degree of the whole mechanical structure is reduced, and the stability is improved.

Owner:南京东利来光电实业有限责任公司