
Patents
Literature
341 results about "Coke burner" patented technology
Efficacy Topic
Property
Owner
Technical Advancement
Application Domain
Technology Topic
Technology Field Word
Patent Country/Region
Patent Type
Patent Status
Application Year
Inventor
Automatic control method for air introduction amount of dry quenching furnace
The invention discloses an automatic control method for the air introduction amount of a dry quenching furnace, and relates to the technical field of dry quenching, and the method comprises the following steps: collecting CO and H concentration distribution data and dust concentration gradient data in an annular flue of the dry quenching furnace, and boiler inlet temperature and circulating gas flow in real time; establishing a multi-parameter coupled dynamic prediction model, and predicting coke burn-out rates and boiler thermal efficiency under different air introduction amounts; an optimal air introduction amount threshold value is calculated through a model prediction control algorithm; on the basis of the optimal air introduction amount threshold value, the opening degree of an electric valve of an air introduction pipe is dynamically adjusted, meanwhile, displacement compensation of a servo mechanism at the position of an introduction opening in the annular flue is triggered, and an introduction point is made to be located in the optimization interval of the CO concentration, the Hconcentration and the dust concentration all the time; and a self-adaptive correction module is established, when it is detected that coke maturity is abnormal and coke discharge temperature fluctuation is abnormal, a compensation control mode based on deep reinforcement learning is automatically switched, and dynamic prediction model parameters are updated.

Owner:BEIJING ZHIYE INTERNET TECH CO LTD
Collision detection method and device for claying mechanical arm
The invention provides a collision detection method and device for a claying mechanical arm, and relates to the technical field of coke oven slurry smearing robots, and the method comprises the following steps: S1, obtaining a movement environment data set, and calculating according to the movement environment data set to obtain a modeling parameter set of the claying mechanical arm and a wall body; s2, a modeling parameter and dynamic radius mapping table is obtained, envelope modeling is conducted on the claying mechanical arm and the wall according to the modeling parameter and dynamic radius mapping table and the modeling parameter set, and a bounding box set is obtained; the type of the bounding box comprises a sphere bounding box and a capsule bounding box; s3, selecting two bounding boxes from the bounding box set according to a preset sequence; if the two bounding boxes are both spherical bounding boxes, first-class collision detection is carried out on the two bounding boxes; if one of the two bounding boxes is a sphere bounding box and the other one is a capsule bounding box, carrying out second-class collision detection on the two bounding boxes; if the two bounding boxes are capsule bounding boxes, carrying out third-class collision detection on the two bounding boxes; obtaining a collision detection result; and S4, operation of the claying mechanical arm is controlled according to the collision detection result. By setting three different types of collision detection, high-precision real-time collision detection of the claying mechanical arm is realized on the premise of not increasing hardware complexity, and the safety and reliability of claying operation are remarkably improved.

Owner:WUHAN UNIV OF SCI & TECH +1
Locomotive driving risk prediction method and system, electronic equipment and storage medium
The invention provides a locomotive driving risk prediction method and system, electronic equipment and a storage medium, and belongs to the field of equipment safety, the method comprises the following steps: obtaining first data, second data and third data, the first data being point cloud data collected by a laser radar on a locomotive, and the second data being point cloud data collected by a laser radar on the locomotive; the second data and the third data are driver images collected by an external camera and a cab camera on the locomotive respectively; performing feature extraction on the first data to obtain a first feature data set; performing feature extraction on the second data to obtain a second feature data set; performing feature extraction on the third data to obtain driver behavior sign data; obtaining a third feature data set related to the driving risk of the coke oven locomotive based on the first feature data set and the second feature data set; and inputting the third feature data set and the driver behavior sign data into a risk early warning model to obtain a driving risk prediction result of the coke oven locomotive. The operation safety and reliability of the locomotive can be improved, and support is provided for intelligent operation.

Owner:河北中增智能科技有限公司
Brick surface targeted slurry laying system and method based on robot
The invention belongs to the technical field of coke oven masonry, and particularly discloses a brick surface targeted slurry laying system and method based on a robot. Comprising a robot; the slurry laying module comprises a feeding unit and a discharging port connected with the feeding unit, the feeding unit is used for conveying slurry with specified pressure to the discharging port, and the discharging port is clamped at the tail end of a robot; the visual module is used for acquiring visual information of the robot, the discharge port and the coke oven masonry; and the control module is used for planning a motion track of the robot according to the visual information, calculating an angle error and a position error of the robot according to an expected pose of the discharge port, and compensating a joint angle and a joint position of the robot according to the angle error and the position error. And the robot drives the discharge port to perform accurate laying on the specified brick surface according to the preset motion trail. According to the invention, multi-face brick directional laying can be realized, and the slurry laying precision and efficiency are high.

Owner:CHINA FIRST METALLURGICAL GROUP
Intelligent control method and system for pressure of gas collecting pipe of coke oven
The invention provides an intelligent control method and system for pressure of a gas collecting pipe of a coke oven, and particularly relates to the technical field of automatic control of the coking production process. According to the method, a coke oven gas collector pressure measured value and an air blower rear pressure value are obtained in real time, and the gas collector pressure change rate is calculated accordingly. When the pressure change rate exceeds a set threshold value, a feed-forward control amount for adjusting the blower speed or the backflow flap opening degree is generated based on the pressure change rate. Meanwhile, the front suction value of the primary cooler is obtained, and feedback control quantity is generated through a feedback control algorithm according to the deviation between the front suction value and the suction set value. And superposing the feedforward control quantity and the feedback control quantity to generate a final control instruction, and adjusting the rotating speed of an air blower or the opening degree of a backflow turning plate according to the final control instruction, so that the measured pressure value of the gas collecting pipe tends to a target pressure set value. According to the method, control delay caused by medium flowing is eliminated, instant and advanced adjustment is achieved, and the problem that control response is not timely is solved.

Owner:XIAN ZHONGCHENG AUTOMATION ENGINEERING CO LTD
Economical single-hole combustion chamber temperature adjusting device
The utility model relates to the technical field of coke oven heating, in particular to an economical single-hole combustion chamber temperature adjusting device, which is characterized in that the input end of each heating gas unit I and the input end of each heating gas unit II are respectively connected with a heating gas main pipe; the output end of each first coal gas heating unit and the output end of each second coal gas heating unit are connected with the corresponding combustion chamber, one end of each adjusting unit is connected with the corresponding first coal gas heating unit, and the other end of each adjusting unit is connected with the corresponding second coal gas heating unit. The utility model has the advantages that the structure realizes the communication of the two heating gas main pipes, one regulating valve can be adopted to complete the flow regulation of the two gas heating pipes in the same combustion chamber, and the on-line maintenance and manual regulation are realized by changing the opening position of the T-shaped plug valve; the regulating valve is connected with the stop valve through the three-way connector, it is guaranteed that the regulating valve can be detached at any time when breaking down, and normal production is not affected.

Owner:ACRE COKING & REFRACTORY ENG CONSULTING CORP DALIAN MCC
Extrusion forming device suitable for coke oven glazed brick
The invention relates to the technical field of brick machines, and discloses an extrusion forming device suitable for coke oven glazed bricks, which comprises a feeding mechanism and a forming mechanism, the forming mechanism comprises a forming die, a hydraulic assembly used for extruding and forming raw materials and an ejection assembly used for ejecting brick bodies formed through extrusion. The forming die is provided with a plurality of side-by-side vertically-through forming groove bodies. According to the extrusion forming device for the glazed bricks of the coke oven, through the unique design of the filler assembly, the problems that powder raw materials are prone to accumulation, adhesion, uneven distribution and the like in the automatic filling process are systematically solved; the partition bodies are arranged in the filling hopper, so that the raw materials are accurately and directionally filled into a plurality of parallel forming groove bodies, the consistency and accuracy of the filling amount of each brick body are fundamentally ensured, and the sizes and the densities of finished bricks are uniform as much as possible.

Owner:SHANDONG WANQIAO GROUP
Bracket structure for chute area of dry quenching furnace
PendingCN113755187AImprove masonry qualityExtended service lifeCoke quenchingMortar jointStructural engineering
The invention relates to a bracket structure for a chute area of a dry quenching furnace. The bracket structure is formed by building a plurality of layers of bracket bricks; and a plurality of supporting pieces are arranged between every two adjacent layers of bracket bricks, the supporting pieces are hard supporting pieces, the thickness of the supporting pieces is the same as that of mortar joints, the top faces of the supporting pieces make direct contact with the upper layer of bracket bricks, and the bottom faces of the supporting pieces make direct contact with the lower layer of bracket bricks. The supporting pieces are placed in the refractory mortar joints between the bracket brick layers, so that the problems of sinking of the annular air duct and cracking of the chute partition wall caused by deformation of the bracket mortar joints and inaccurate bracket elevation control are effectively prevented, the masonry quality of the dry quenching furnace is improved, and the service life of the dry quenching furnace is prolonged.
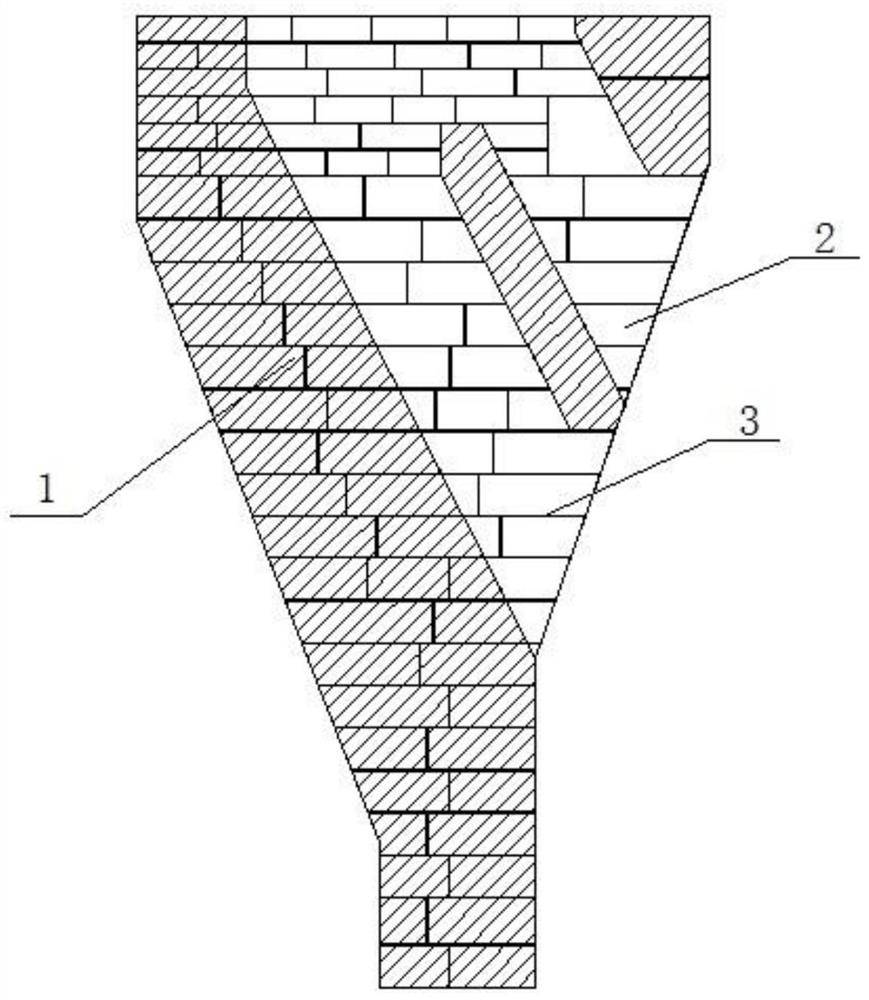
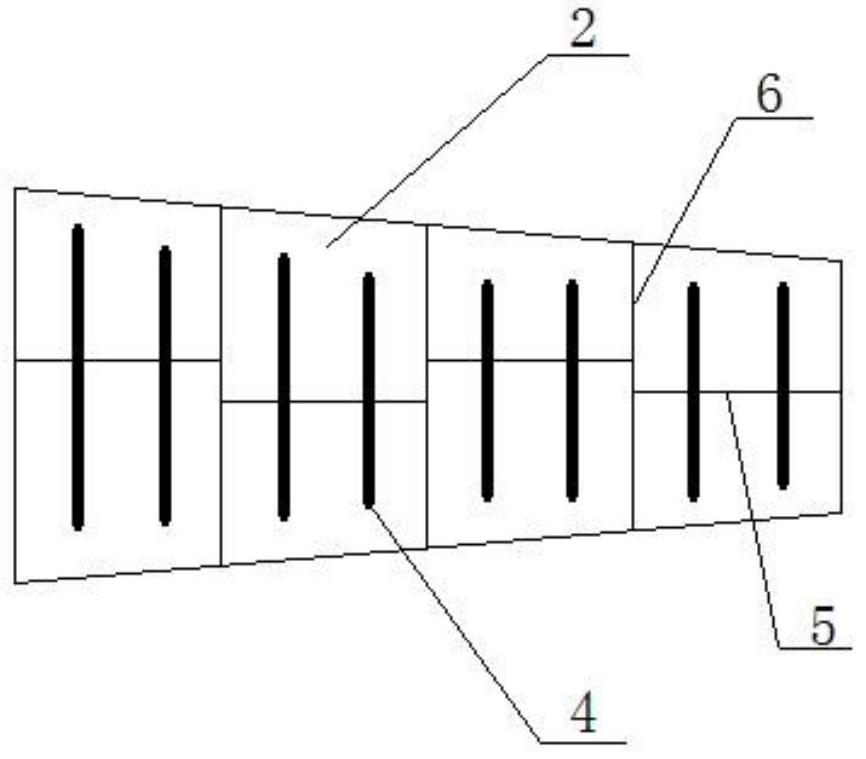
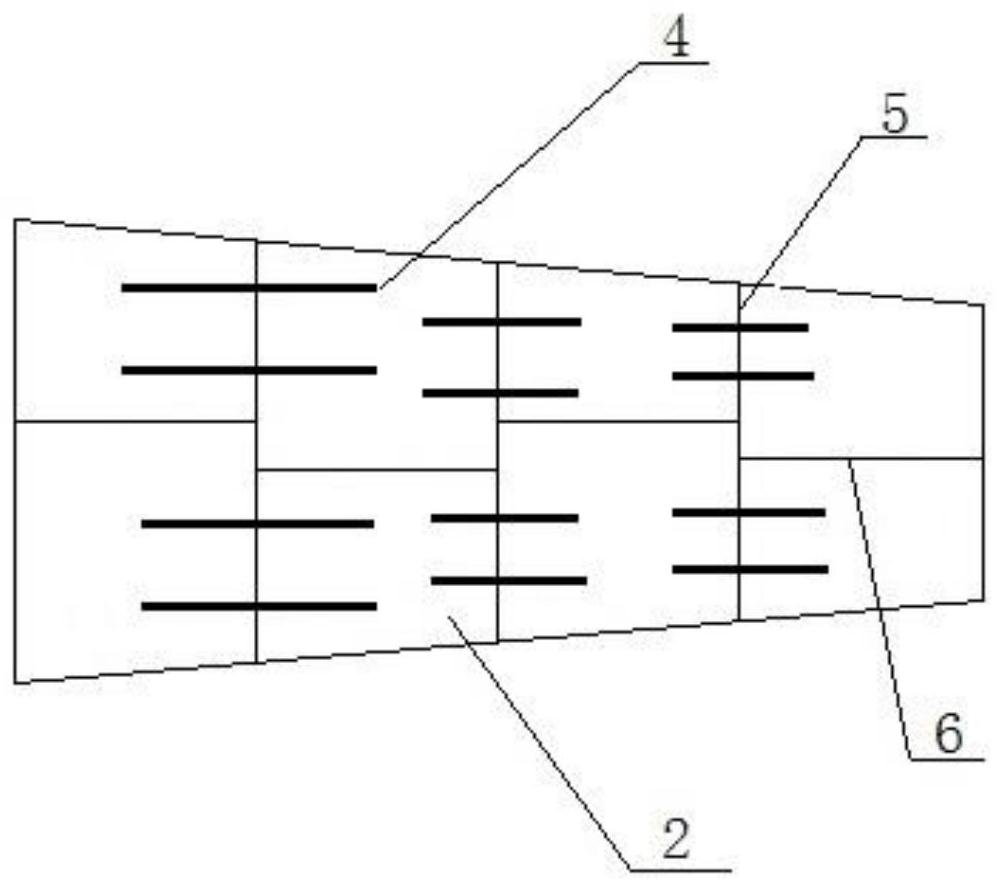
Owner:ACRE COKING & REFRACTORY ENG CONSULTING CORP DALIAN MCC
Coke oven combustion chamber vertical flue module based on pouring process and construction method
PendingCN120648478ACombustible gas coke oven heatingCoke oven brickworkCombustion chamberCoke burner
The invention discloses a coke oven combustion chamber vertical flue module based on a pouring process and a construction method, the module comprises a first assembly module which comprises a first module main body (1), a partition wall module (2) and a separation layer (5), and a second assembly module which comprises a second module main body (16), a partition wall module (2), a separation layer (5) and an adjustable template for pouring the assembly modules, the adjustable template comprises a positive and negative thread supporting device (6), a wooden wedge (7), a U-shaped clamp (8), an outer die (9), a hole channel core die (10), a first arc groove die (11), a second arc groove die (12), a stepped caulking template (13), an inner die (14) and a bottom die (15), the adjustable template is made of a high-strength metal material, and the adjustable template with enough rigidity and stability is accurately erected according to the actual size of a combustion chamber. According to the module and the construction method, the repairing efficiency, stability and safety of the coke oven combustion chamber are remarkably improved.

Owner:CHINA FIRST METALLURGICAL GROUP
Furnace chamber temperature monitoring device of heating furnace for recycling waste mineral oil
InactiveCN120489364AThermometer detailsThermometers using electric/magnetic elementsThermodynamicsCoke burner
The invention relates to the technical field of temperature monitoring, in particular to a hearth temperature monitoring device of a heating furnace for waste mineral oil recycling, which comprises a furnace body and a chimney, a burner and a furnace tube are arranged in the furnace body, and the burner is used for heating waste mineral oil in the furnace tube; a movable detection mechanism for monitoring the temperature of the furnace tube is arranged in the furnace body; the movable detection mechanism comprises a movable detection frame arranged outside the furnace tube, the movable detection frame is installed in the hearth through a lifting screw and a guide rod, one end of the lifting screw is fixedly connected with a lifting motor installed outside the furnace body, and the lifting motor is used for driving the movable detection frame to move up and down along the lifting screw and the guide rod. The device has the characteristics of omnibearing and accurate temperature detection, oil product coking prevention and furnace tube damage prevention, and solves the problems that an existing hearth temperature monitoring device is only provided with sensors at several points, the temperature distribution condition of the whole hearth cannot be comprehensively mastered, some local overheated or overcooled areas can be omitted, and coking is caused.

Owner:HUBEI ANNAIJI ENVIRONMENTAL PROTECTION TECH CO LTD
Conversion system and conversion process for preparing methanol from coke oven gas
PendingCN120838323AOrganic compound preparationHydroxy compound preparationGas compressorCoke burner
The invention provides a conversion system and a conversion process for preparing methanol from coke oven gas, and relates to the technical field of processes for preparing methanol from coke oven gas. The conversion system for preparing methanol from coke oven gas comprises an oxygen supply module at least provided with an air separation oxygen supply unit and an oxygen supply compressor which are communicated with each other; a mixing module having at least a first mixing unit and a second mixing unit; and the conversion module is communicated with the first mixing unit and the second mixing unit. Wherein the oxygen supply compressor is further communicated with a liquid oxygen supply unit, and the liquid oxygen supply unit is used for supplementing supplied oxygen; the first mixing unit is communicated with the oxygen supply compressor, and the first mixing unit is communicated with a steam generator and carbon dioxide supply equipment; the second mixing unit is communicated with the steam generator and the coke-oven gas compressor; the first mixing unit is provided with a first heating device; and the second mixing unit is provided with a second heating device. The conversion rate of methanol synthesized from coke oven gas can be improved.

Owner:SICHUAN DAXING ENERGY CO LTD
Coke oven roof repair or replacement
A method of repairing or replacing a roof of a coke oven battery in operation, said coke oven battery including a number of parallel coking chambers separated by heating walls and delimited on top by a ceiling, itself covered by a roof, the roof having for each coking chamber a number of charging holes or gas transfer holes above the coking chamber, a number of inspection holes above the separating heating walls, one or two base rings connected to one or two gas collecting mains and rail sleepers supporting rails for a coke charging car or charging gas transfer car through an ascension pipe. A kit of parts with construction modules and the use of such kit of parts in the repairing or replacing of a roof of a coke oven battery in operation and or with at least one oven empty in hot condition is also related.

Owner:PAUL WURTH SA
A ramming type coke oven gas collecting device
ActiveCN224313451UDispersed particle filtrationTransportation and packagingMolecular sieveCoke burner
This utility model discloses a tamping-type coking oven gas collection device. A gas collecting pipe and a negative pressure pipe are installed at the top of the coking oven. The negative pressure pipe connects to a heat energy cascade recovery assembly, a spray device, and a filter assembly. The valve at the front end of the negative pressure pipe is automatically flipped by a combined drive assembly. The combined drive assembly uses a baffle, slide rod, and rack and pinion linkage to drive the valve using gas pressure, with a spring assisting in reset, achieving dynamic pressure balance in the system. The screw can adjust the initial opening of the valve. The heat energy cascade recovery assembly includes high-temperature, medium-temperature, and low-temperature heat exchangers, increasing the gas heat energy recovery rate to 60-70%. The filter assembly uses a porous ceramic layer and a molecular sieve layer to effectively remove micron-sized particles and molecular-level impurities. This device requires no additional power, can precisely control pressure, efficiently recover heat energy, and purify gas, solving problems such as energy waste, pressure runaway, and insufficient filtration in traditional devices. It improves the safety and economy of coking oven operation and is suitable for tamping-type coking oven gas collection.


Owner:ANSHAN BAINAI MASCH EQUIP MFG CO LTD
Fixed tooth groove liquid level type coke oven single carbonization chamber raw gas pressure adjusting device
The utility model provides a fixed tooth groove liquid level type coke oven single carbonization chamber raw gas pressure adjusting device which comprises a valve body and a valve plate, the valve body is of a cylindrical structure, the valve plate is of a tray type structure, the lower end of the valve body is connected with an inner cylinder in a sealed mode, a plurality of open holes are formed in the cylinder wall of the lower end of the inner cylinder, the side wall of the valve plate is connected with the lower end of the valve body, and an opening of the tray type structure is upward. When the bottom face of the valve plate swings to the horizontal position, the lower end of the inner cylinder can be located in the disc type structure of the valve plate, and the height of the top end of the opening is smaller than that of the disc opening edge of the valve plate. The pressure regulating device is used as a water-sealed valve for regulating the pressure of raw gas in a coke oven carbonization chamber, and can effectively control the discharge of liquid and regulate the pressure of the raw gas through the design of a tooth groove structure. The device can effectively control the pressure while rapidly reducing the pressure of the raw gas, and can solve the problem that the pressure regulation amplitude of the existing device is small.

Owner:NANJING HUADIAN ENERGY SAVING & ENVIRONMENTAL PROTECTION EQUIP
A coke oven flue gas desulfurization pulp preparation control method
The present application belongs to the technical field of desulfurization pulping, and relates to a coke oven flue gas desulfurization pulping control method. A slurry distributor is connected to a pulping digestion tank, and the slurry distributor is arranged in parallel with a vibrating screen, so that the slurry discharge direction of the slurry distributor is parallel to the vibrating screen, the impact of the slurry on the vibrating screen is reduced, the width of the slurry discharge port is expanded through the slurry distributor, and the slurry is uniformly discharged onto the vibrating screen. The slurry distributor comprises a distributor shell and baffles. One end of the distributor shell is provided with a slurry inlet, and the other end is provided with a slurry discharge port. The slurry inlet is communicated with the pulping digestion tank through a slurry downpipe. The baffles are multiple and are arranged between the slurry inlet and the slurry discharge port. The baffles guide the slurry from the slurry inlet to the slurry discharge port. The present application guides the slurry through the slurry distributor, so that the slurry discharge direction is parallel to the vibrating screen and the width of the discharge port is expanded, the problem of impacting the vibrating screen during the lime slurry discharging process is solved, the splashing of the slurry is reduced, and the effect of the vibrating screen is improved.

Owner:CHONGQING IRON & STEEL CO LTD
Rapid-ignition and strong-wind-resistance nanometer ceramic heating body ignition gun for coke oven ascending pipe
The invention relates to the technical field of ignition guns for coke oven ascension pipes, in particular to a quick-ignition and strong-wind-resistance nanometer ceramic heating body ignition gun for a coke oven ascension pipe. Comprising a porous protective gun head, a 90-degree bent gun body and a junction box which are connected in sequence, the nano ceramic crystal heating body is arranged in the porous protective gun head and is used for raising the temperature to 800 DEG C or above within 2 seconds; a plurality of vent holes distributed in an annular array are formed in the front end of the porous protective gun head, so that wind-resistant flames are formed; the gun body bent by 90 degrees comprises an inner heat insulation layer and an outer gun barrel arranged outside the inner heat insulation layer in a sleeving mode, and a heat insulation gap is formed between the inner heat insulation layer and the outer gun barrel. The junction box is of a modular structure and is arranged at the tail end of the gun body. The device can be quickly started, has strong wind interference resistance and extreme high temperature resistance, and is convenient to maintain.

Owner:ACRE AUTOMATION CO LTD MCC +1
Brick positioning and supporting device of coke oven furnace end masonry robot
The utility model provides a brick positioning and supporting device of a coke oven furnace end masonry robot, which belongs to the technical field of coke oven construction engineering and comprises a stand column, a linear sliding table and a limiting mechanism. The linear sliding table is installed on the stand column, one end of the limiting mechanism is connected with the linear sliding table, and the linear sliding table can drive the limiting mechanism to move in the direction of the stand column. And the limiting mechanism is used for limiting the position of the furnace end masonry. The furnace end brickwork is limited and supported by the limiting mechanism through the lifting of the linear sliding table, so that the requirements of different wall widths can be met. By means of the design, the integrity of masonry is guaranteed, and bricks on the two sides are prevented from moving due to extrusion force in the masonry process.

Owner:CHINA FIRST METALLURGICAL GROUP
Preparation method of organic silicon separation membrane and application of organic silicon separation membrane in separation of coke-oven gas
PendingCN121082123ASemi-permeable membranesDispersed particle separationCeo2 nanoparticlesPhysical chemistry
The preparation method comprises the following steps: dispersing CeO2 nanoparticles in absolute ethyl alcohol containing diluted hydrochloric acid, activating, adding a certain amount of a silane coupling agent and diluted hydrochloric acid, carrying out a water bath reaction for a certain time, separating after the reaction is finished to obtain a surface-modified CeO2 nanoparticle crude product, and purifying to obtain the organic silicon separation membrane. The CeO2 nanoparticles with the modified surfaces are obtained; dissolving an organic silicon precursor 1, 2-bis (triethoxysilyl) ethylene in absolute ethyl alcohol, adding deionized water and diluted hydrochloric acid, heating and stirring to form a Si-OH intermediate, stirring and adding the surface modified CeO2 to obtain CeO2 modified organic silicon sol; coating a porous aluminum oxide ceramic tube with the CeO2 modified organic silicon sol, and calcining to obtain a CeO2 modified separation membrane; compared with an organic silicon separation membrane modified by noble metal, the separation membrane prepared by the method is relatively low in cost, good in stability in a complex gas environment and relatively good in hydrogen selectivity.

Owner:CIMC ENRIC ENGINEERING TECHNOLOGY CO LTD +2
A coke oven door and frame cleaning device
This utility model relates to a coke oven door and frame cleaning device, belonging to the field of coke oven cleaning technology. It includes a hollow column and multiple laser gun heads. A protective box is vertically slidable on the front side of the hollow column. A cable outlet box communicating with the interior of the protective box is fixedly connected to the lower rear end of the protective box. A cover plate is detachably fastened to the front opening of the protective box. Multiple laser gun heads are arranged horizontally and equidistantly inside the protective box. This utility model uses high-power laser beams emitted by the laser gun heads to irradiate impurities adhering to the surface of the oven door and frame, causing them to evaporate or decompose due to heat, thereby effectively removing impurities from the oven door and frame and achieving the cleaning purpose. Compared with traditional scraper-type cleaning, this laser cleaning method significantly improves the cleaning speed and can clean dead corners that scrapers cannot reach. Furthermore, laser cleaning does not require direct contact with the oven door and frame, thus avoiding wear and tear that may result from mechanical contact.

Owner:SHANXI PINGYAO NO 1 MINE COKING CO LTD
Coke oven flue gas desulfurization and regeneration integrated tower
ActiveCN224236393UFully contactedImprove desulfurization effectDispersed particle filtrationRotary stirring mixersThermodynamicsPtru catalyst
The utility model relates to the technical field of flue gas desulfurization, in particular to a coke oven flue gas desulfurization and regeneration integrated tower which comprises a bottom plate, the top of the bottom plate is fixedly connected with a control plate and a desulfurization cylinder respectively, a first filter screen is fixedly connected in the desulfurization cylinder, the surface of the first filter screen is fixedly connected with a magnetic plate, and a second filter screen is arranged at the top of the first filter screen. The bottom of the second filter screen is fixedly connected with an iron plate, the iron plate is in magnetic attraction connection with the magnetic plate, an insertion groove is formed in the second filter screen, a third filter screen is arranged at the top of the second filter screen, the bottom of the third filter screen is fixedly connected with an insertion rod, and the insertion rod extends into the insertion groove and is in insertion connection with the insertion groove; a driving motor is mounted at the top of the desulfurization cylinder; the stirring rod can be driven to rotate under the power action of the driving motor, and the catalyst is in full contact with the flue gas through the rotation of the stirring rod, so that the flue gas desulfurization effect and the flue gas desulfurization speed can be improved, and the practicability of the whole device is higher.

Owner:LUOYANG YIXIN ENVIRONMENTAL PROTECTION TECH CO LTD
Auxiliary replacement device
The invention provides an auxiliary replacement device which is used for replacing a walking motor and / or a walking speed reducer of coke oven mobile equipment. The auxiliary replacing device comprises a walking trolley, a synchronous jacking device, a supporting platform, a controller and a power supply device. The walking trolley comprises a trolley frame, a trolley head and a walking wheel set. The synchronous jacking device comprises a hydraulic station and a plurality of jacks arranged on the frame; the supporting platform is arranged at the movable end of each jack, and the supporting platform is used for supporting a walking motor to be disassembled and assembled and / or a walking speed reducer to be disassembled and assembled; when a walking motor and / or a walking speed reducer need to be replaced, only the auxiliary replacement tool needs to be moved to the steel foundation, the height of the supporting platform is adjusted to the position flush with the top face of the steel foundation, and then a part to be replaced can be horizontally pulled to the supporting platform; and finally, replacing and reassembling the parts. And in the whole replacement process, the supporting platform is used for supporting, so that the falling risk of the to-be-replaced part is effectively avoided, and the replacement safety is improved.

Owner:SHANGHAI BAOSTEEL METALLURGICAL CONSTRUCTION CORP
Coke oven flue gas recovery processing device
The utility model belongs to the technical field of coke oven flue gas recovery equipment, and particularly discloses a coke oven flue gas recovery treatment device which comprises a flue gas box, ash guide pipes are symmetrically connected to the two sides of the flue gas box, a first collecting hopper is connected to the upper ends of the ash guide pipes, and a fixing frame is connected to the upper ends of the flue gas box and the first collecting hopper. A movable plate and an air blowing cover are slidably connected in the fixed frame, two rectangular grooves are formed in the movable plate, adsorption plates are arranged in the rectangular grooves, the air blowing cover is connected with an air guide hose, and the other end of the air guide hose is connected with a fan. According to the device, dust in flue gas can be continuously adsorbed and collected, workers do not need to frequently replace the adsorption plate 4, and normal operation of the coke oven cannot be influenced.

Owner:GANSU JIUGANG HONGXING HONGXIANG ENERGY CO LTD
Coke oven combustion chamber structure
The invention relates to a coke oven combustion chamber structure. A plurality of vertical flame paths forming a coke oven combustion chamber are divided into machine side furnace end vertical flame paths, middle vertical flame paths and coke side furnace end vertical flame paths; wherein the side wall of the machine-side furnace end vertical flame path is built by using equal-thickness side wall bricks I, the side wall of the coke-side furnace end vertical flame path is built by using equal-thickness side wall bricks II, and the side wall of the middle vertical flame path is built by using equal-thickness side wall bricks III; the thickness of the first side wall brick is the same as that of the second side wall brick, and the thickness of the third side wall brick is smaller than that of the first side wall brick and that of the second side wall brick. The thickness of the middle vertical flame path side wall bricks is smaller than that of the furnace end vertical flame path side wall bricks on the two sides, the middle vertical flame path side wall bricks are made of the refractory materials with the heat transfer performance better than that of the furnace end vertical flame path side wall bricks on the two sides, the heat transfer performance of the combustion chamber furnace wall is effectively improved, the structure is simple, the number of brick types is small, and the manufacturing cost is low.

Owner:ACRE COKING & REFRACTORY ENG CONSULTING CORP DALIAN MCC
Intelligent flexible safety protective fence for coke oven coil base and manufacturing method of intelligent flexible safety protective fence
The invention belongs to the technical field of smelting in the iron and steel industry, and discloses an intelligent flexible coke oven coil base safety protective fence and a manufacturing method thereof.The intelligent flexible coke oven coil base safety protective fence comprises a follow-up pulley assembly, a movable supporting wheel set, a steel wire rope assembly, a driving pulley assembly, a steel wire rope fixing base, an adjusting spring assembly and an intelligent alarm system; and the follow-up pulley assembly is fixed on the steel wire rope fixing seat through a connecting bolt. The timeliness and reliability of safety protection are improved, the intelligent alarm system and the reflecting plate form a light path through the laser transmitter, when a person gets close to the edge of the coil base and shields the light path, sound-light alarm can be triggered immediately, the problem of response lag of traditional manual patrol is solved, three steel wire ropes are evenly arranged up and down to form three-dimensional protection, and the safety protection effect is improved. And through precise supporting of supporting wheels of the movable supporting wheel set, personnel are effectively prevented from falling, a safety protection cover protects the laser device against environmental interference, it is ensured that early warning is stable, and potential safety hazards are greatly reduced.

Owner:ANSTEEL ENG TECH CORP
Connecting structure for coke oven door lining brick fixing bolts
The utility model discloses a connecting structure for coke oven door lining brick fixing bolts, which comprises two fixing base plates, the number of the fixing base plates is two, the fixing base plates are respectively and horizontally arranged on two sides along the longitudinal direction, and the fixing base plates on the two sides are respectively provided with a plurality of vertically arranged anchor bolts I in a combined manner through connecting and positioning components. The device has the beneficial effects that the coaxiality of the thread bushing and the matching hole can be ensured, so that the accurate coaxiality of the screw rod part I at the top of the anchor bolt I is ensured after the screw rod part I is coaxially matched with the thread bushing, and the condition that the anchor bolt I is not vertical to the top surface of the fixed base plate is avoided; the perpendicularity of the first anchoring bolt and the fixing base plate is guaranteed, it is guaranteed that the first anchoring bolt can be accurately limited and compared with the hole position of the furnace door frame, and therefore it is guaranteed that the furnace door lining brick can be smoothly and stably fixed to the furnace door frame in the mode that the first anchoring bolt is additionally provided with a locking nut.

Owner:REFRACTORY MATERIAL OF SINOSTEEL CORP
Intelligent planning and scheduling method for complex cross-operation vehicles
The invention discloses an intelligent planning and scheduling method for complex cross-operation vehicles, which belongs to the technical field of metallurgical coking and comprises the following steps: acquiring state information and position information of an elevator, interferent conditions near the elevator, a working mode and position information of a quenching car, a state of a coke tank and a material level state of a dry quenching furnace; based on the state information of the elevator or the material level state of the dry quenching furnace, judging the working mode of the elevator, the quenching car or the dry quenching furnace: a normal production mode, a material driving mode or an independent mode; and based on the working mode of the elevator, the quenching car or the dry quenching furnace, determining the optimal working path plan of the quenching car and the elevator, and giving the operation task determination of coke receiving, coke conveying or tank receiving of the quenching car and the elevator. According to the invention, the risk of man-vehicle cross operation is eliminated, and unattended operation in a high-risk area is realized; the turnover period of the coke tank is shortened; the utilization rate of the dry quenching furnace is improved, and a standardized normal form for full-automatic transfer of a complex logistics system is provided.

Owner:DALIAN HUARUI INTELLIGENCE TECH CO LTD +1
A coke oven locomotive accurate positioning system and positioning method
The present application belongs to the field of coking production, and solves the problem of accurate alignment of coke oven car and oven mouth. The present application relates to a coke oven car accurate positioning system and positioning method. The system comprises a moving main body connected with a coke oven car to be positioned. The moving main body comprises a top plate with a bottom plate assembly at its lower end. A connecting plate is fixed to the middle of the rail away from the coke oven at the lower end of the bottom plate assembly. A main support plate is arranged below the connecting plate. The main support plate and the connecting plate are connected through a plurality of positive pressure mechanisms. Two measuring rolling wheels are installed below the main support plate, which are in contact with the rail and coaxially arranged with measuring encoders. Four dust sweeping assemblies are installed below the bottom plate assembly. An inductor is installed at the starting point and the terminal point of the moving main body. An inductive sensor is installed near each end of the main support plate. A Hall module is installed on the main support plate. Eight magnetic block columns are arranged near each coke oven door. The system further comprises a single-chip microcomputer, a digital display instrument and an upper computer management system. The present application improves the alignment accuracy of the oven door.

Owner:CHINA STATE SHIPBUILDING CORP NO 707 RES INST +1
A coke oven flue gas SCR denitration process reagent intelligent control management system

Owner:ANSTEEL ENG TECH CORP
Rail type coke oven temperature measuring robot and translation type coke oven temperature measuring hole furnace cover
The invention relates to the technical field of coking temperature measuring equipment, in particular to a rail type coke oven temperature measuring robot and a translation type coke oven temperature measuring hole furnace cover, the translation type coke oven temperature measuring hole furnace cover comprises a cover body, a pin column is arranged at the top of the cover body, and the upper portion of the cover body is connected with a translation guide mechanism and a reset part. The translation guide mechanism comprises a sliding seat and a fixed seat, guide grooves connected with the edge of the temperature measuring hole are formed in the two sides of the fixed seat, the sliding seat slides along the guide grooves in the fixed seat, a reset part is arranged at the end, away from the temperature measuring hole, of the fixed seat and comprises a columnar spring, one end of the columnar spring abuts against the end of the fixed seat, and the other end of the columnar spring abuts against the end of the fixed seat. And the other end is propped against one end of the sliding seat. Translation uncovering is achieved in cooperation with an uncovering translation shifting rod of the rail type coke oven temperature measurement robot, automatic reset is achieved through the reset part, and temperature measurement is completed.

Owner:TANGSHAN CHENGDA INTELLIGENT TECH CO LTD
A regulating device for a mixed gas orifice plate butterfly valve in a coke oven basement and a method for controlling the gas flow.
PendingCN122281054AKeep fixed throttling functionContinuous automatic adjustmentCoke burnerHeat control
This invention provides a regulating device for a butterfly valve orifice plate for mixed gas in a coke oven basement, comprising a valve body, a continuous regulating mechanism for the butterfly valve, and a fixed throttling mechanism for the orifice plate. The inner cavity of the valve body serves as a gas flow channel, and the continuous regulating mechanism for the butterfly valve is installed within the channel perpendicular to the gas delivery direction. The continuous regulating mechanism for the butterfly valve is a structure that continuously and steplessly adjusts the opening and closing of the butterfly plate through a pneumatic actuator to achieve different gas flow rates. The fixed throttling mechanism for the orifice plate is an integrated throttling structure arranged within the channel along the gas delivery direction, and is sealed by a self-tightening lever clamping mechanism. The invention also provides a method for controlling gas flow using this device, which solves the problems of coarse regulation, the need to replace the orifice plate, and operational hazards associated with traditional orifice plate valves. It achieves continuous and precise regulation of gas flow without the need to replace the orifice plate, significantly improving the coke oven heating control level and system safety. It is particularly suitable for coke oven basement gas pipeline systems where space is limited and safety requirements are extremely high.


Owner:NANJING ZHIBAO ENERGY SAVING & ENVIRONMENTAL PROTECTION TECH CO LTD